OT-2026-000003119
Vacuum manipulation device
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003119
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- SCHMALZ KURT, SCHMALZ WOLFGANG
- Assignee
- SCHMALZ J GMBH
- Original source
- US-6168220-B1, the United States Patent and Trademark Office, 2 January 2001
- Document SHA-256
- a5a3e21b110b303677a0040ccb33d8c35e2a9260f9a501dcf5a071e2e0e7ebce
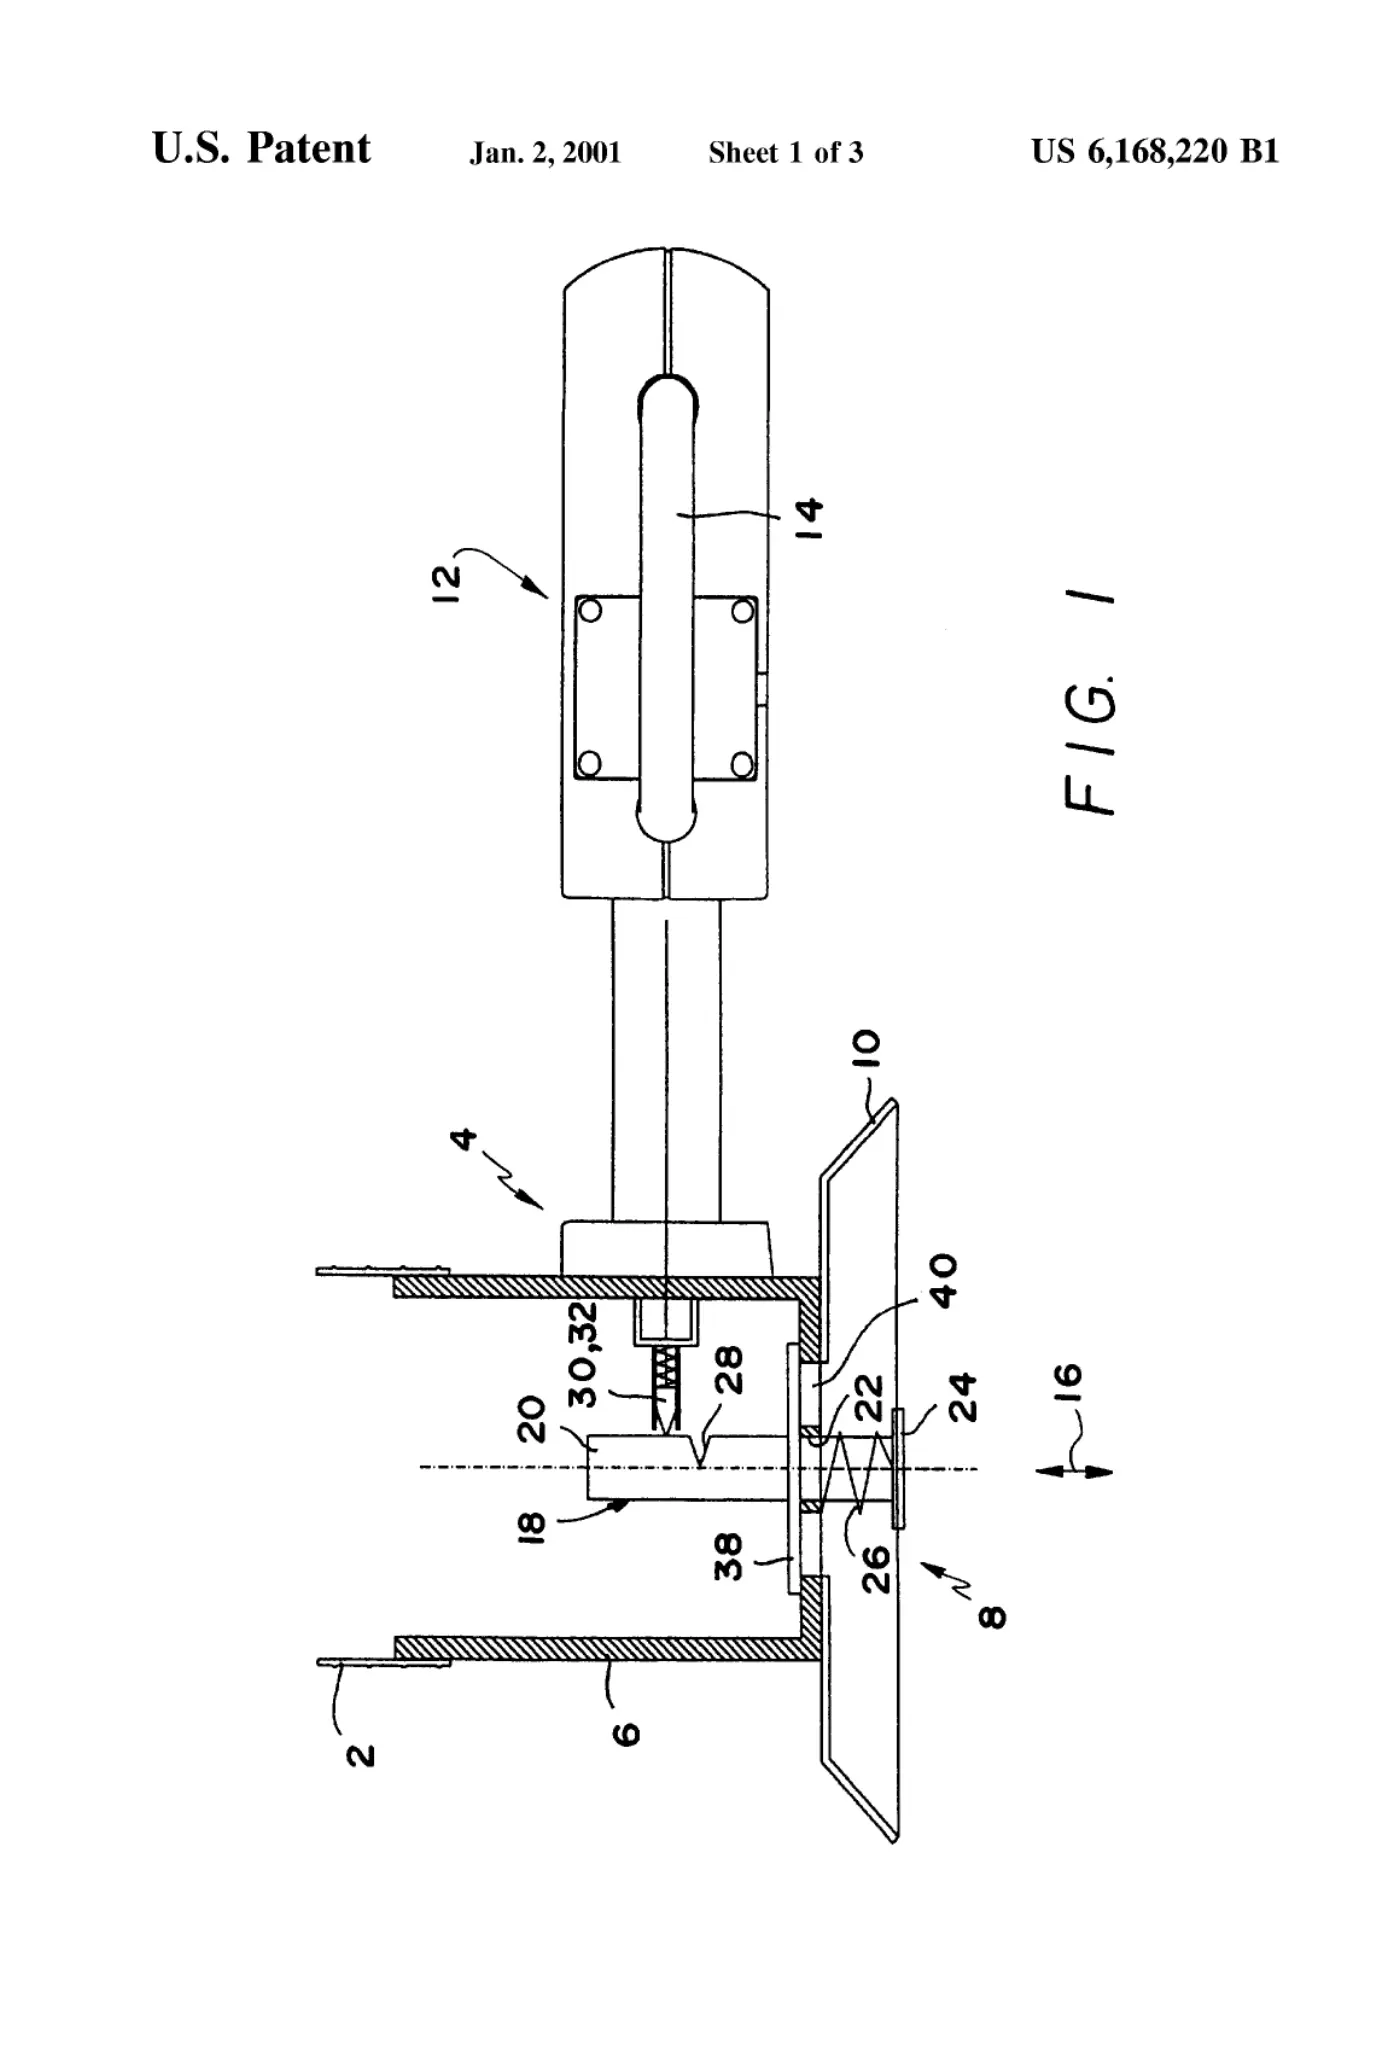
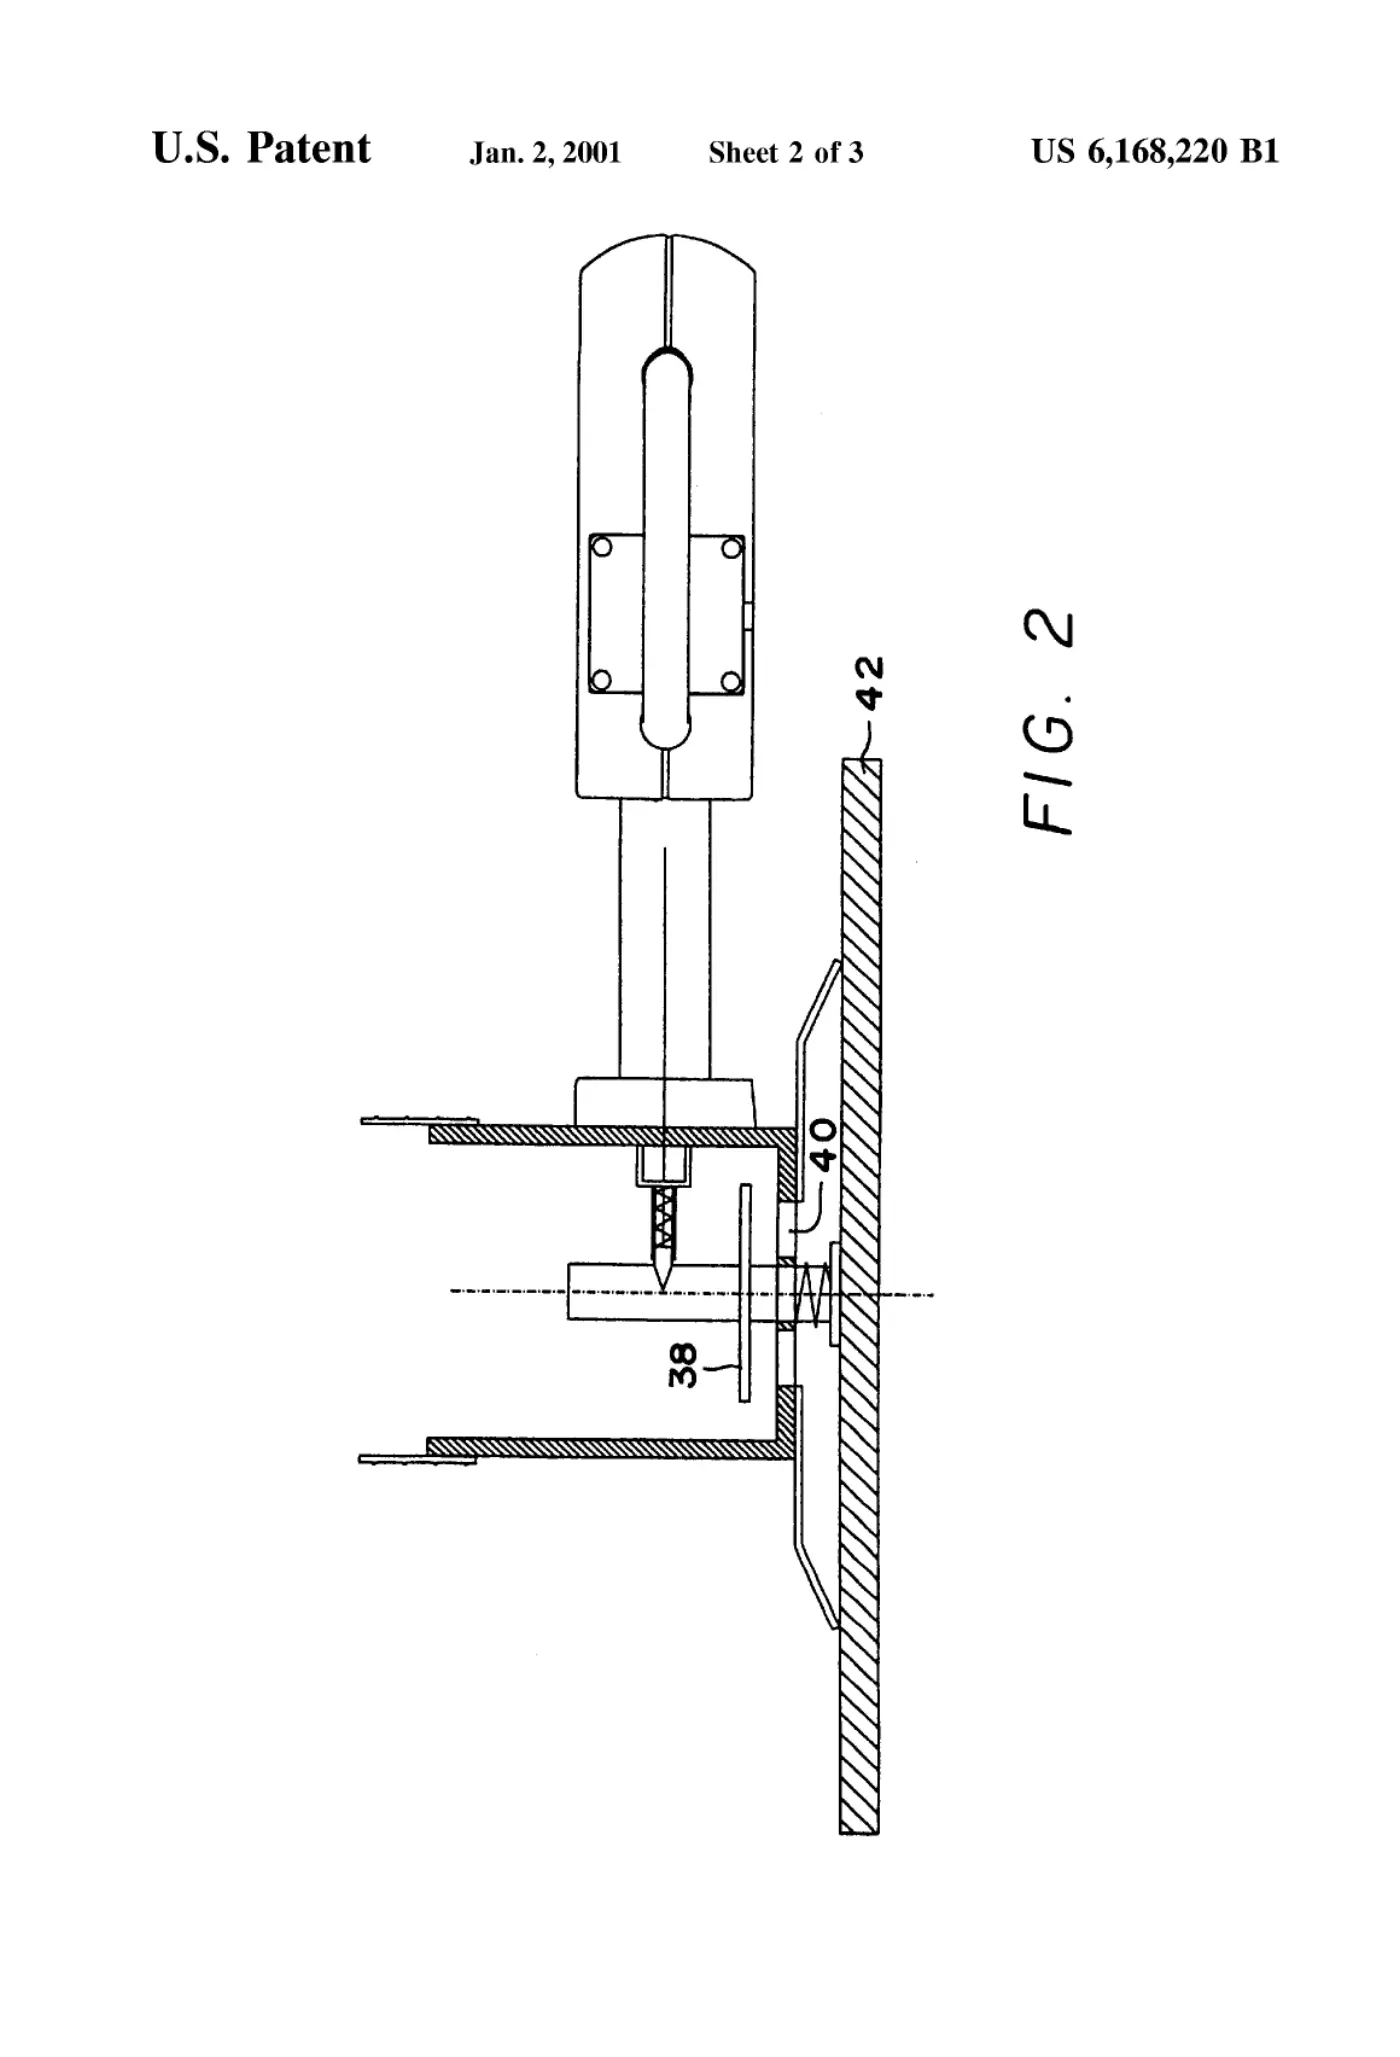
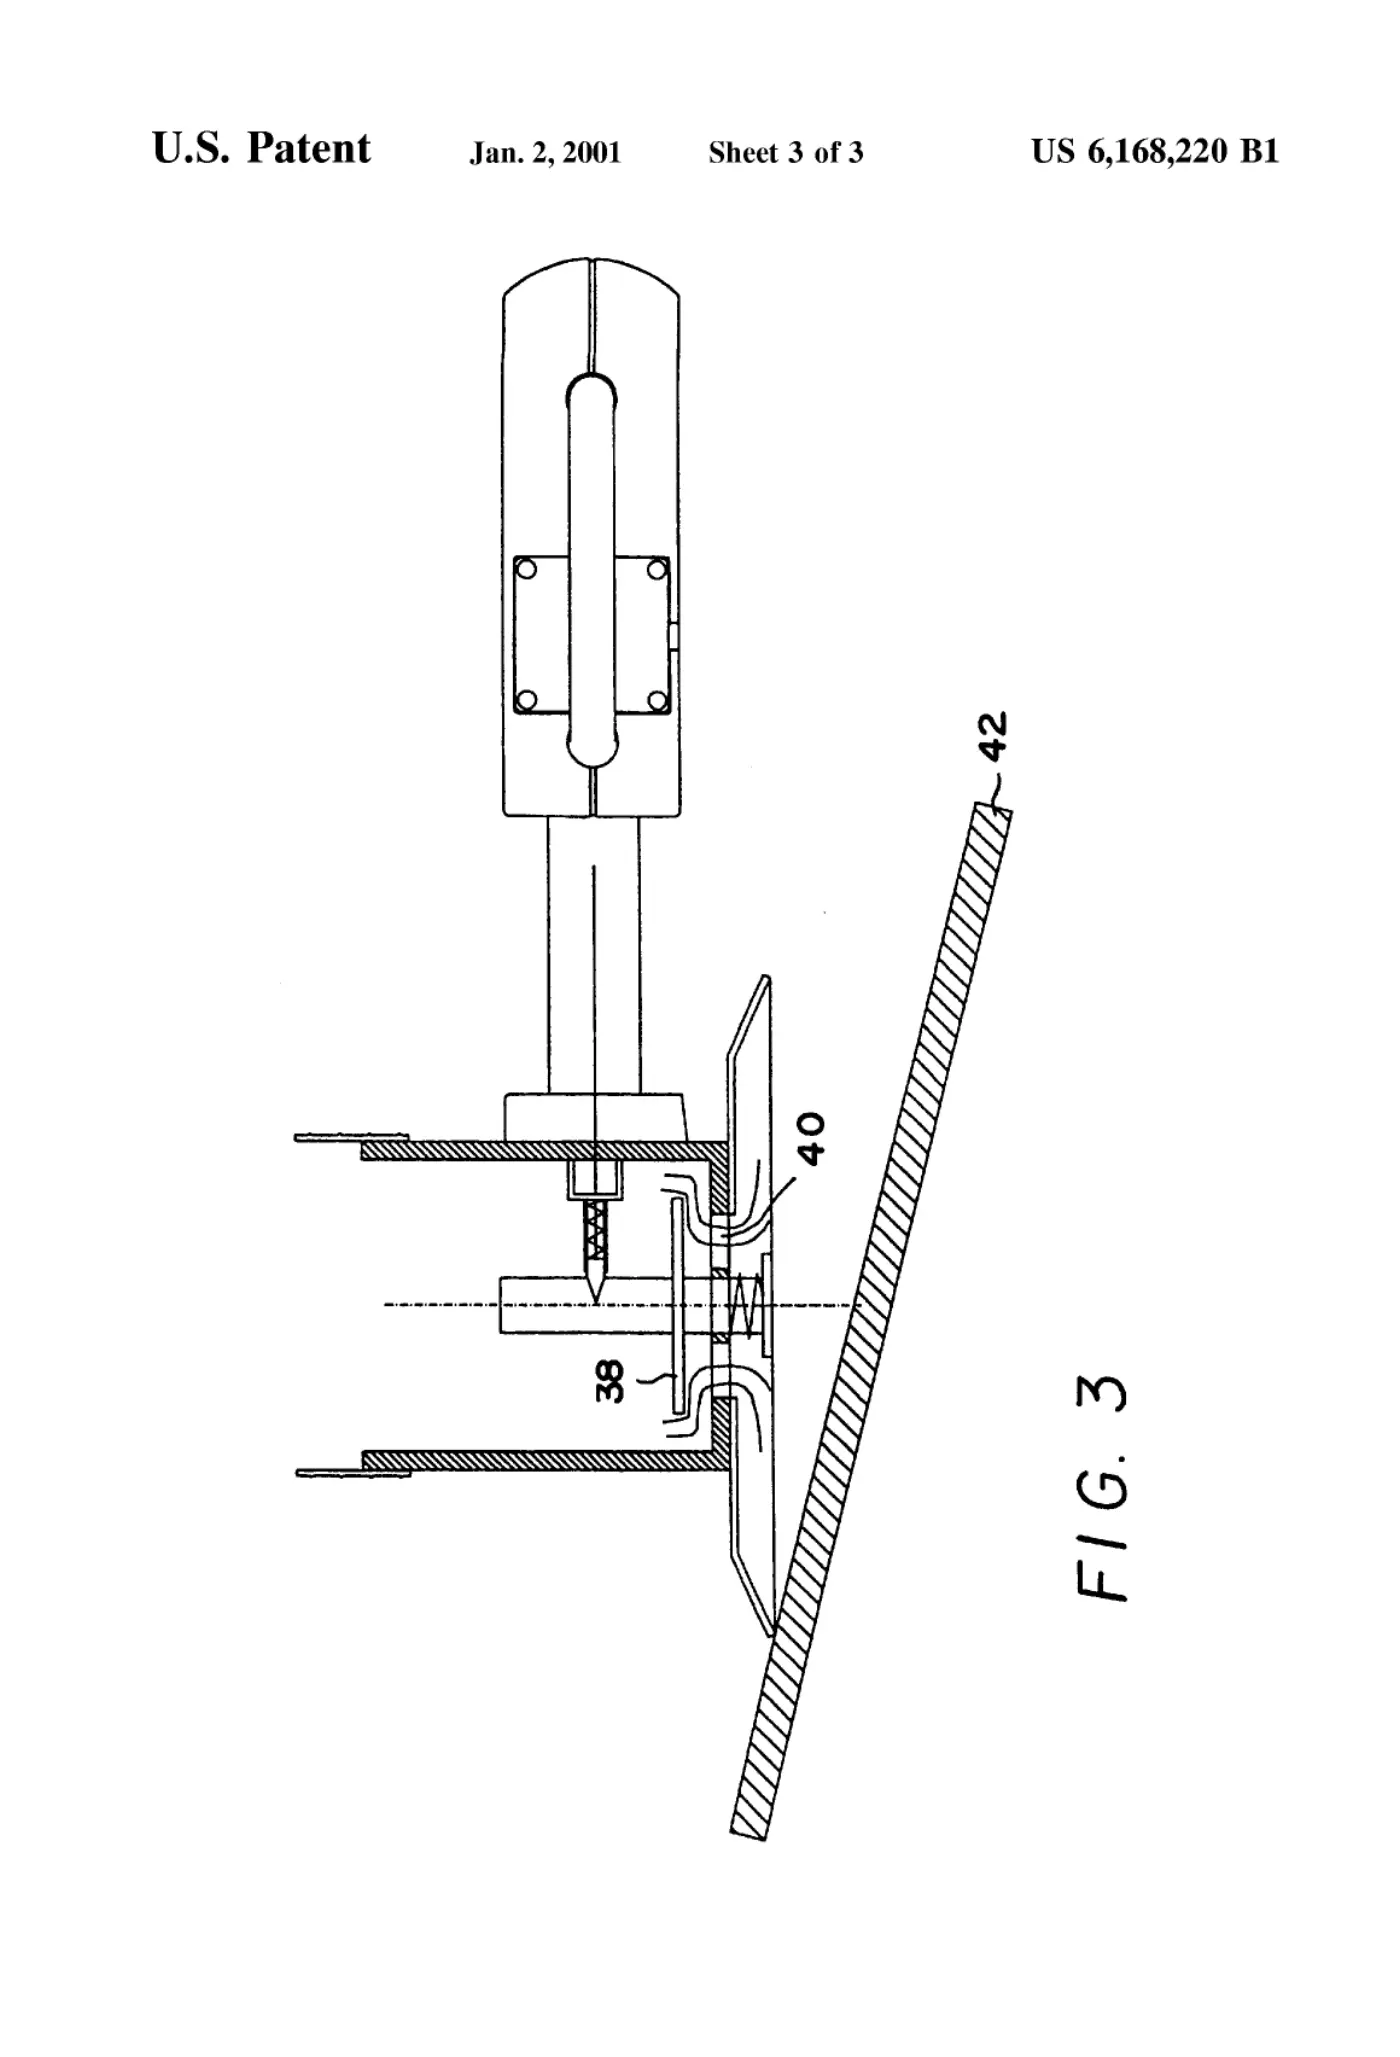
The present invention relates to a vacuum manipulation device having a lifter hose, which can be connected to a vacuum-generating device, and a suction gripper device, which can be placed on an object to be manipulated and with which the object can be drawn up by suction and lifted by contracting the lifter hose, the suction gripper device has a prestressed regulating member on its suction side, which is actuated by placing the suction gripper device on the object and which thereby unblocks a flow cross-section, so that the object can be drawn up by suction. To prevent the abrupt upward acceleration of the suction gripper device, the regulating member can be arrested in its actuated position, so that in case of the release of a drawn-up object from the suction side of the suction gripper device the flow cross-section is not again blocked, and in this way the abrupt upward acceleration of the suction gripper device is prevented.
Abstract
The present invention relates to a vacuum manipulation device having a lifter hose, which can be connected to a vacuum-generating device, and a suction gripper device, which can be placed on an object to be manipulated and with which the object can be drawn up by suction and lifted by contracting the lifter hose, the suction gripper device has a prestressed regulating member on its suction side, which is actuated by placing the suction gripper device on the object and which thereby unblocks a flow cross-section, so that the object can be drawn up by suction. To prevent the abrupt upward acceleration of the suction gripper device, the regulating member can be arrested in its actuated position, so that in case of the release of a drawn-up object from the suction side of the suction gripper device the flow cross-section is not again blocked, and in this way the abrupt upward acceleration of the suction gripper device is prevented.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
Publication information
Citation
OpenTechnical Publication OT-2026-000003119, “Vacuum manipulation device,” published September 15, 2026 at 19:32:52 UTC, https://opentechnical.org/p/OT-2026-000003119.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.