OT-2026-000003134
Explosives disposal robot
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003134
- Classification
- Robotics & Automation › Robot Architectures
- Original source
- US-6113343-A, the United States Patent and Trademark Office, 5 September 2000
- Document SHA-256
- 633d74b2f2f69cbe9ee8ec08281309e0172f08bfbb5b743f73a2dee893ee3e8f
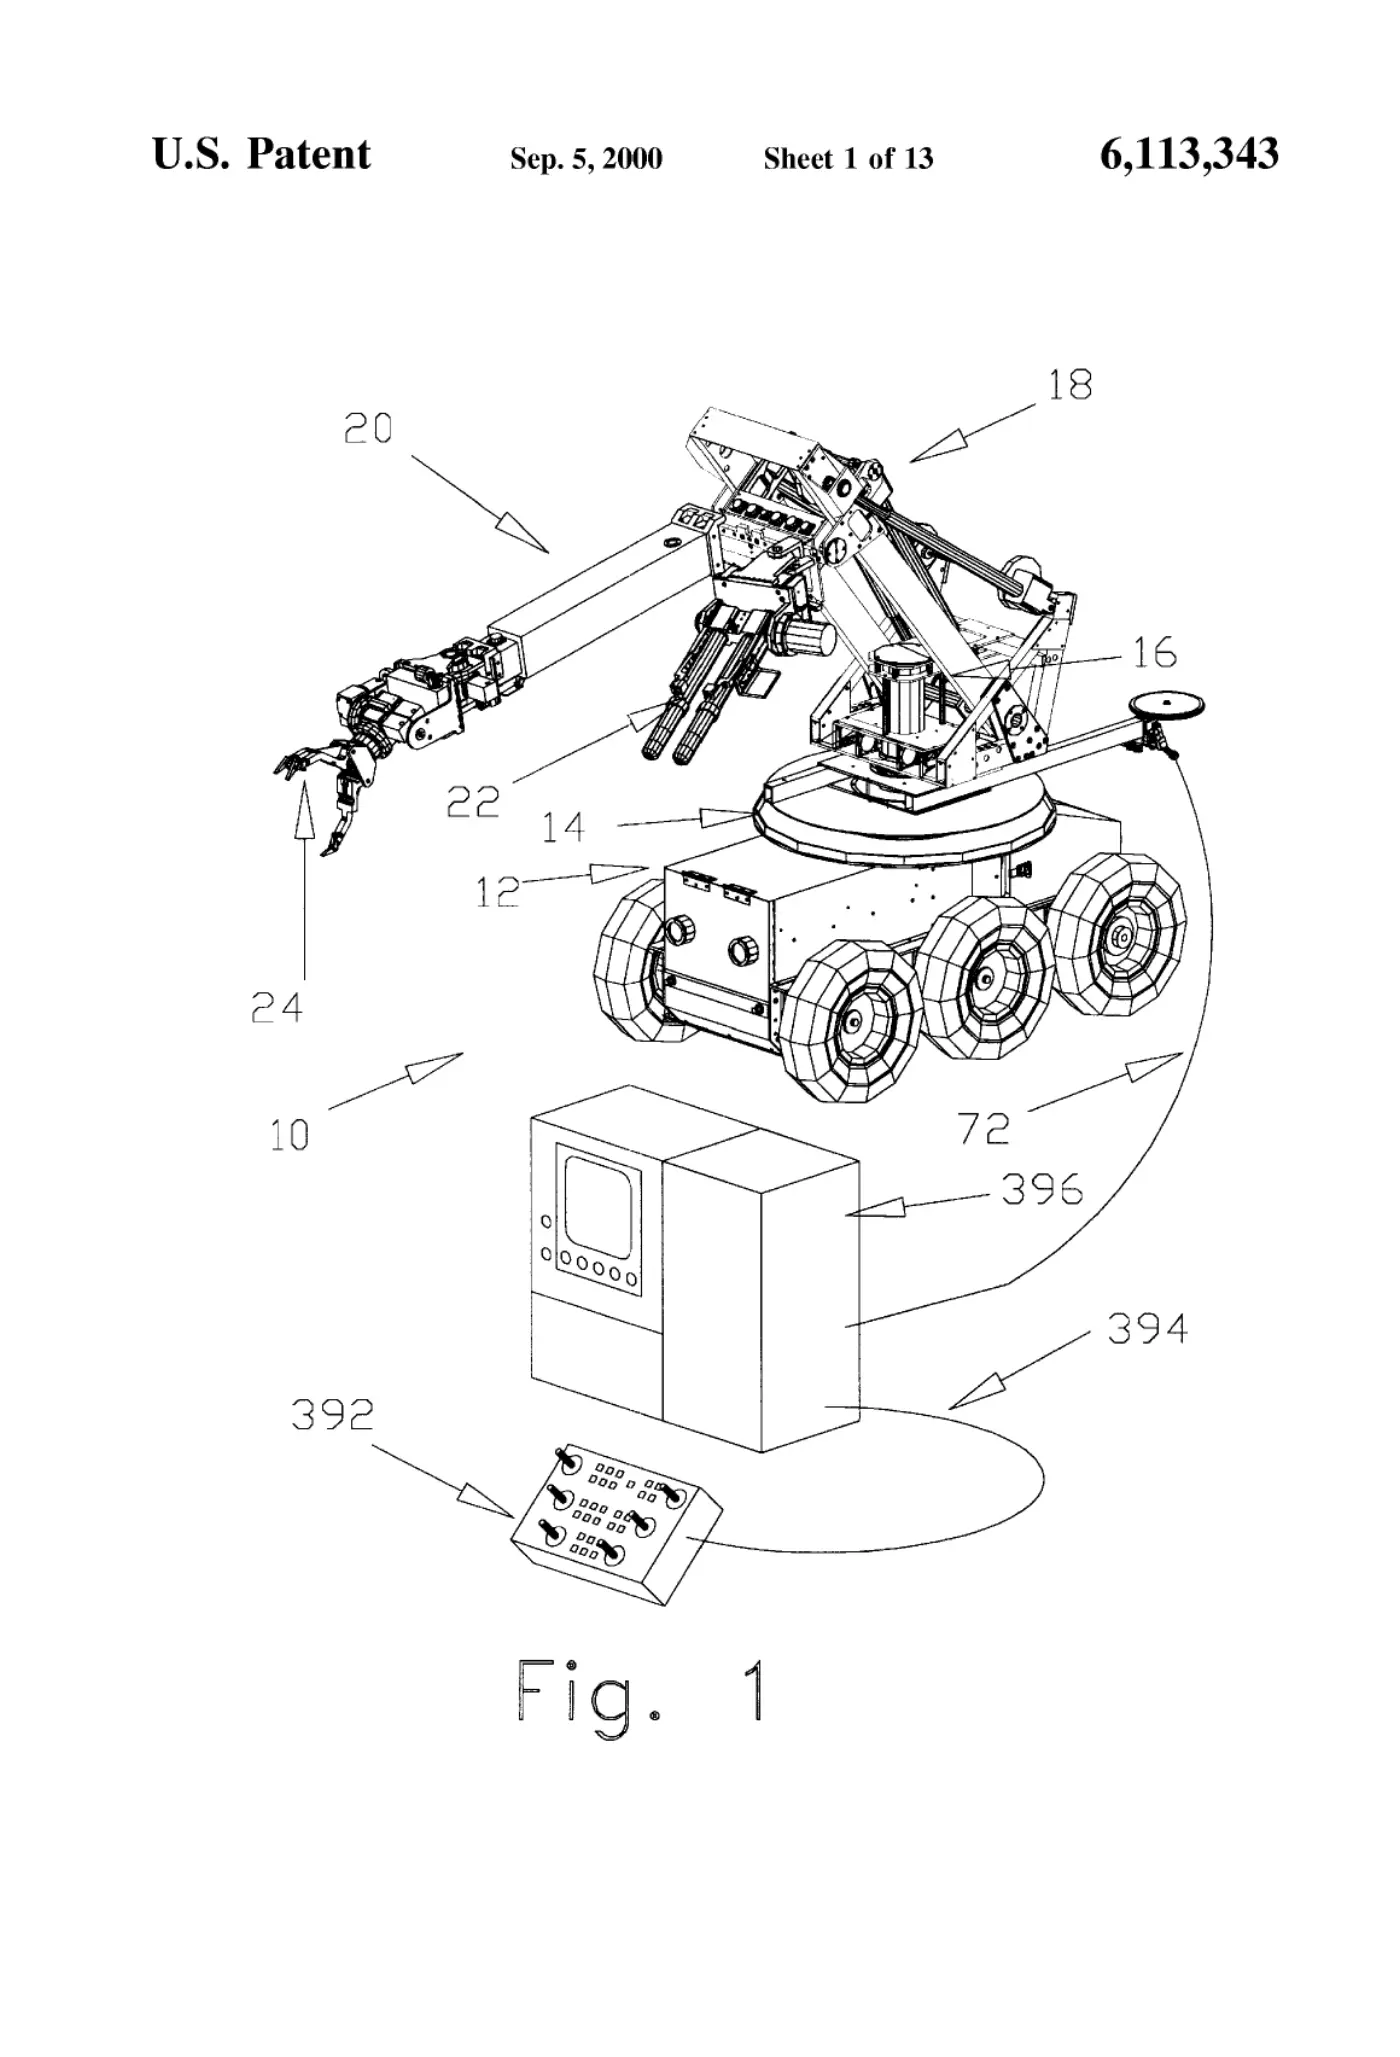
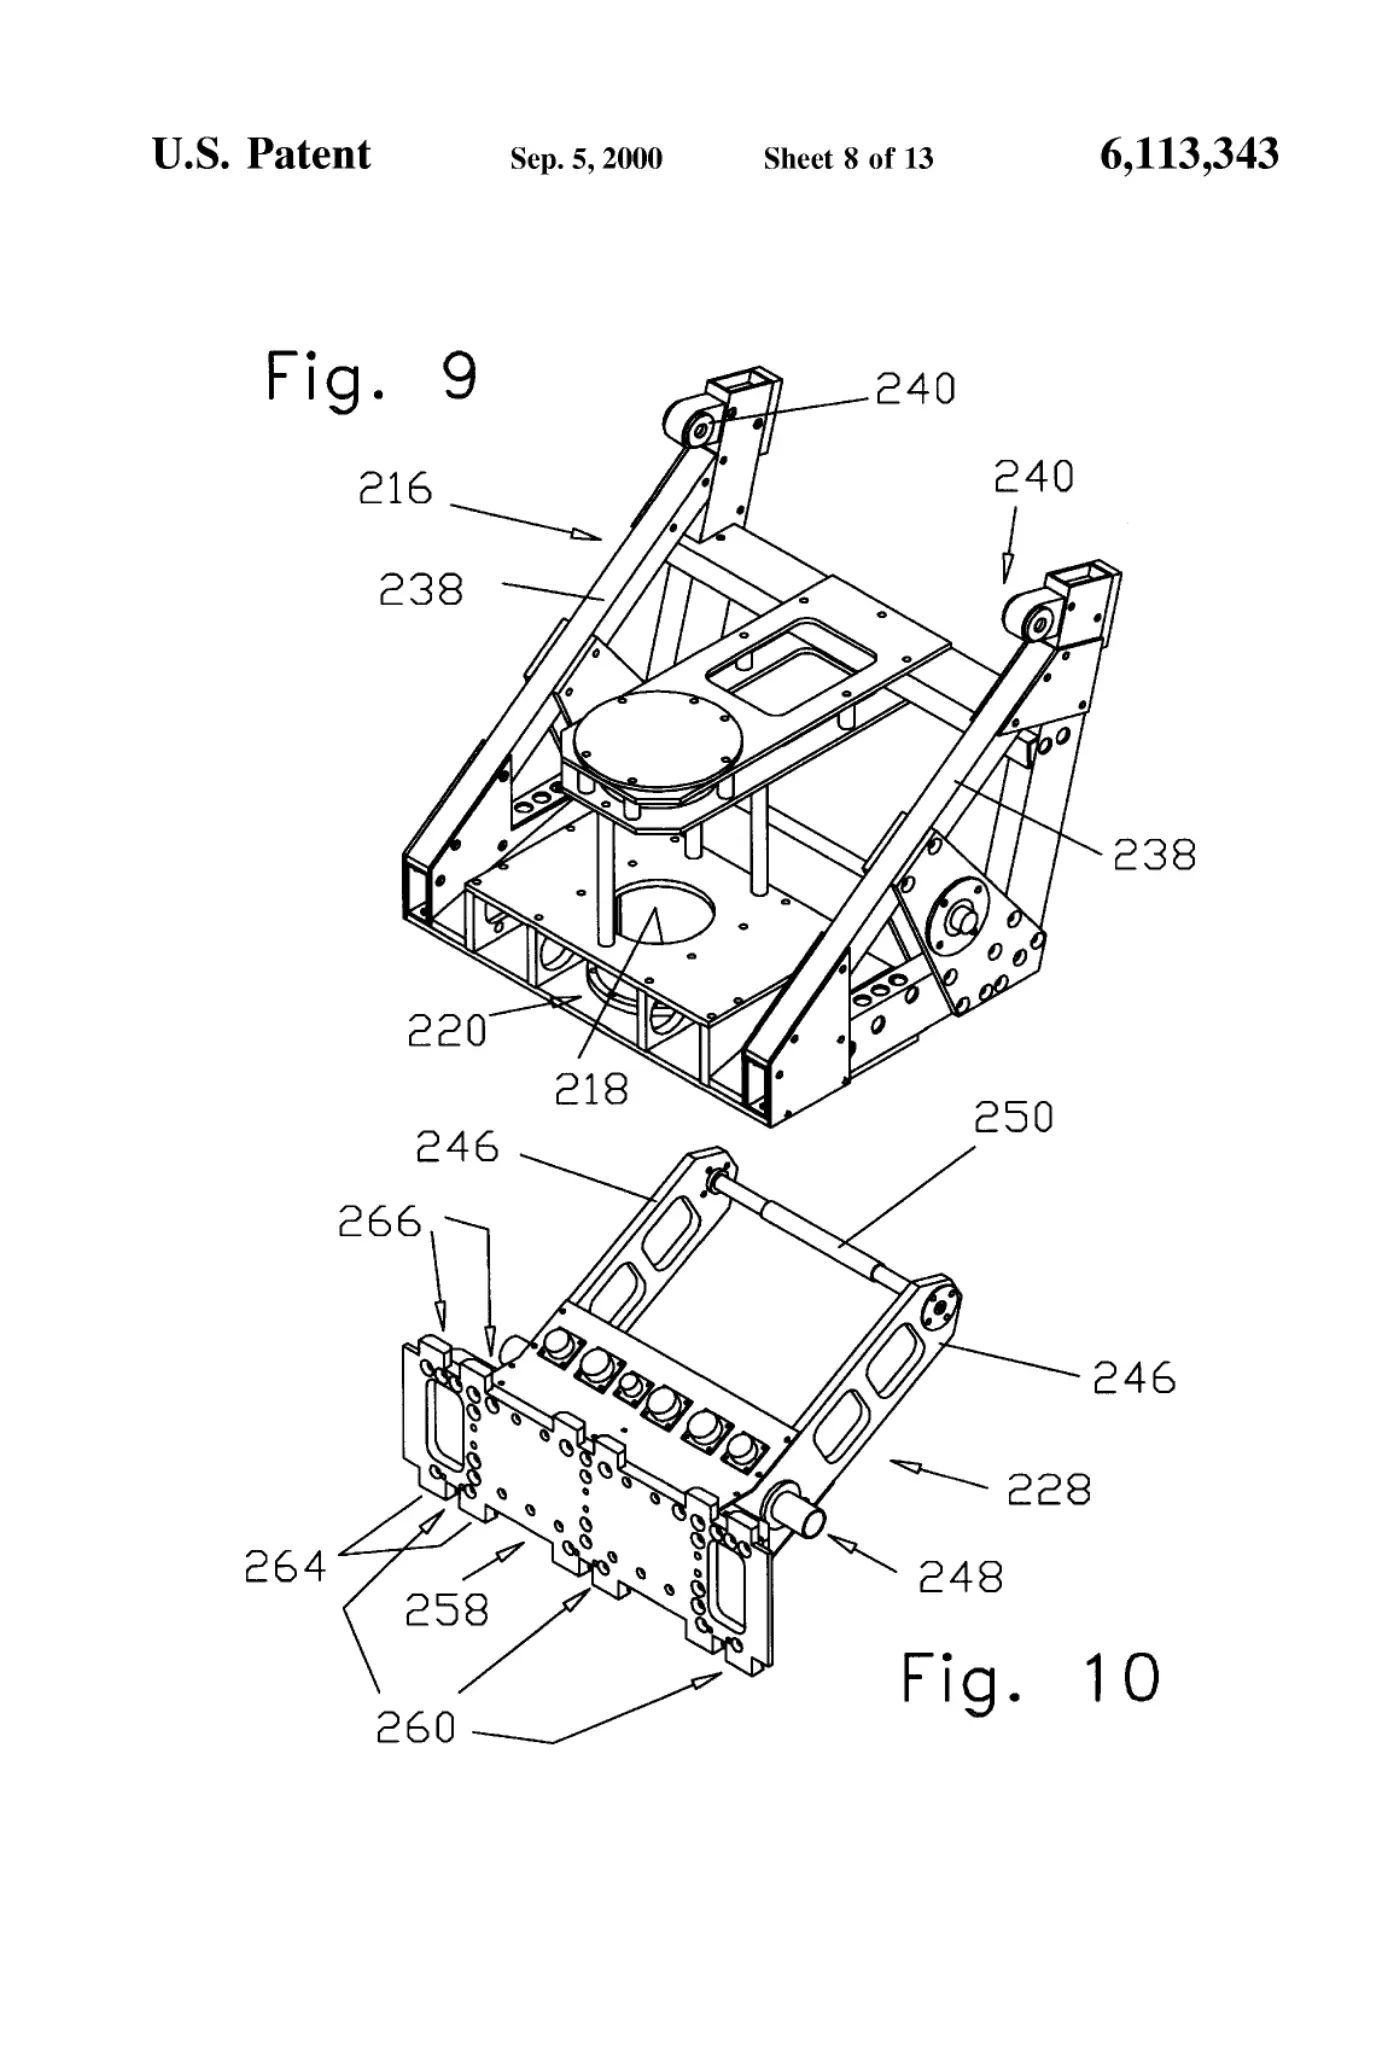
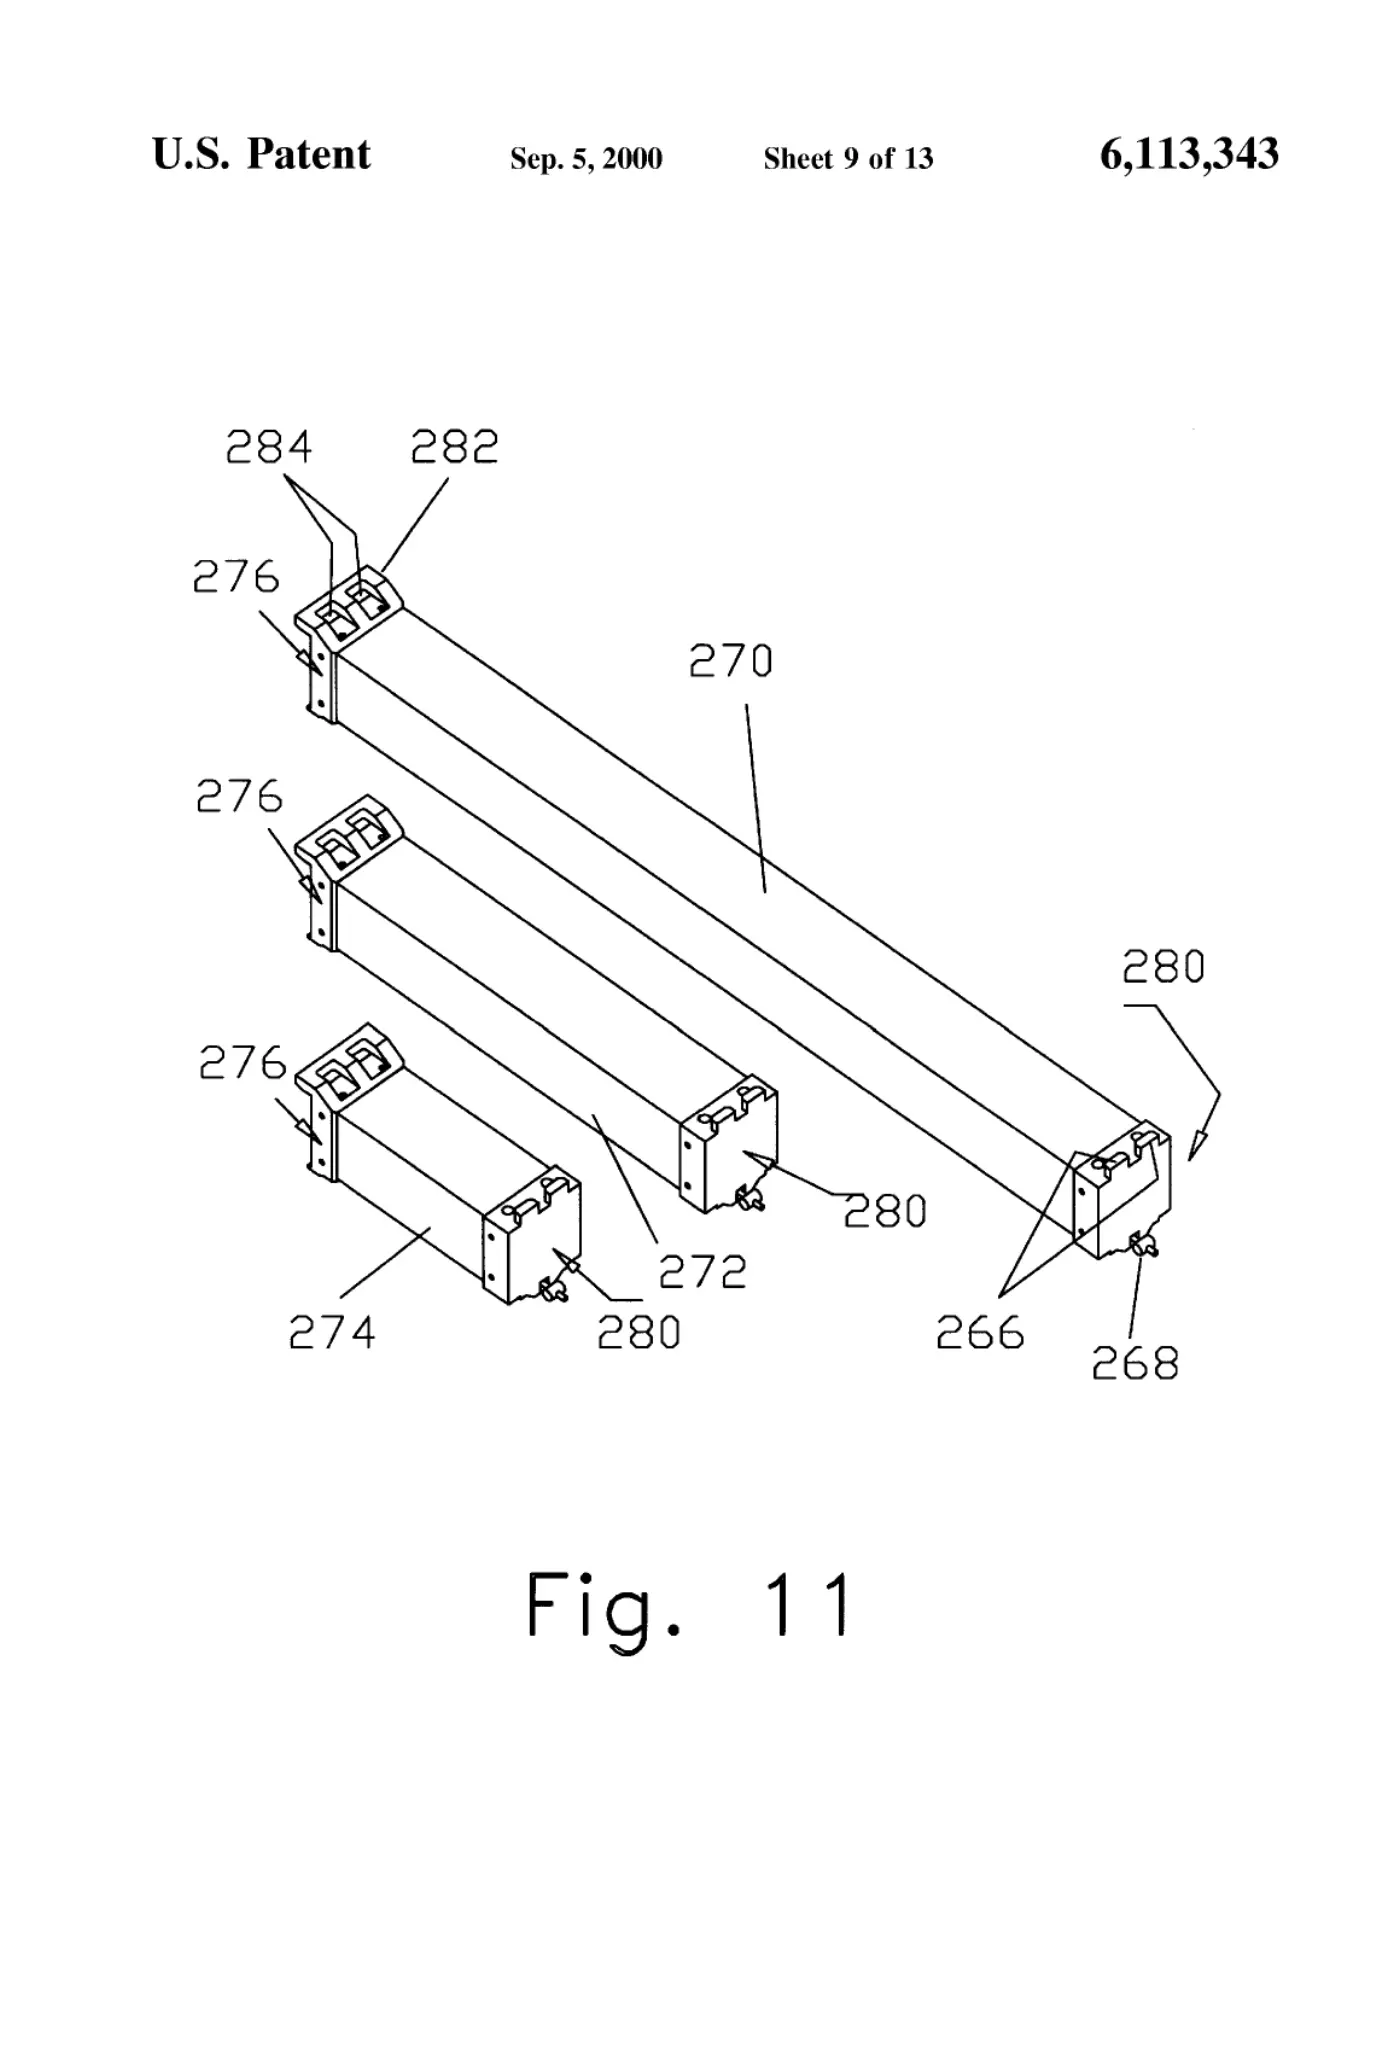
A robot especially adapted for use in hazardous environments, and particularly adapted for explosives disposal, includes a wheeled platform carrying a winder mechanism which ensures that the remote control cable will not be fouled by the robot or its attachments. Coaxial with the winder mechanism is a turret mechanism that can rotate indefinitely and which carries thereon a manipulator arm section which, includes a first arm pivotable through about 110° and which carries thereon a second arm which is pivotable through about 120° and carries a bulkhead to which any of a plurality of end effectors can be connected by way of a quick connect and disconnect mechanism. The end effectors include a set of links having different lengths, one or two extension links, a wrist and gripper mechanism, an aiming and disruptor mechanism, and a relocatable surveillance camera. The robot is capable of controlled movement to or from a hazardous site; manoeuvring the wrist and gripper mechanism or the aiming and disruptor mechanism, by means of the manipulator arm, into close proximity with, to either move or destroy, a target. Rugged, zero-backlash joints blend precision and power for the end effectors to perform delicate, or not so delicate, operations. The wrist and gripper mechanism in combination with any or all of the extension links allows dextrous operations to be performed easily, even for an untrained operator. The robot is compact, highly manoeuvrable, relatively inexpensive, and meets the requirements of law enforcement, military and environmental agencies having a need for such a device.
Abstract
A robot especially adapted for use in hazardous environments, and particularly adapted for explosives disposal, includes a wheeled platform carrying a winder mechanism which ensures that the remote control cable will not be fouled by the robot or its attachments. Coaxial with the winder mechanism is a turret mechanism that can rotate indefinitely and which carries thereon a manipulator arm section which, includes a first arm pivotable through about 110° and which carries thereon a second arm which is pivotable through about 120° and carries a bulkhead to which any of a plurality of end effectors can be connected by way of a quick connect and disconnect mechanism. The end effectors include a set of links having different lengths, one or two extension links, a wrist and gripper mechanism, an aiming and disruptor mechanism, and a relocatable surveillance camera. The robot is capable of controlled movement to or from a hazardous site; manoeuvring the wrist and gripper mechanism or the aiming and disruptor mechanism, by means of the manipulator arm, into close proximity with, to either move or destroy, a target. Rugged, zero-backlash joints blend precision and power for the end effectors to perform delicate, or not so delicate, operations. The wrist and gripper mechanism in combination with any or all of the extension links allows dextrous operations to be performed easily, even for an untrained operator. The robot is compact, highly manoeuvrable, relatively inexpensive, and meets the requirements of law enforcement, military and environmental agencies having a need for such a device.
1. Drawings
[0001]Sheet 1.
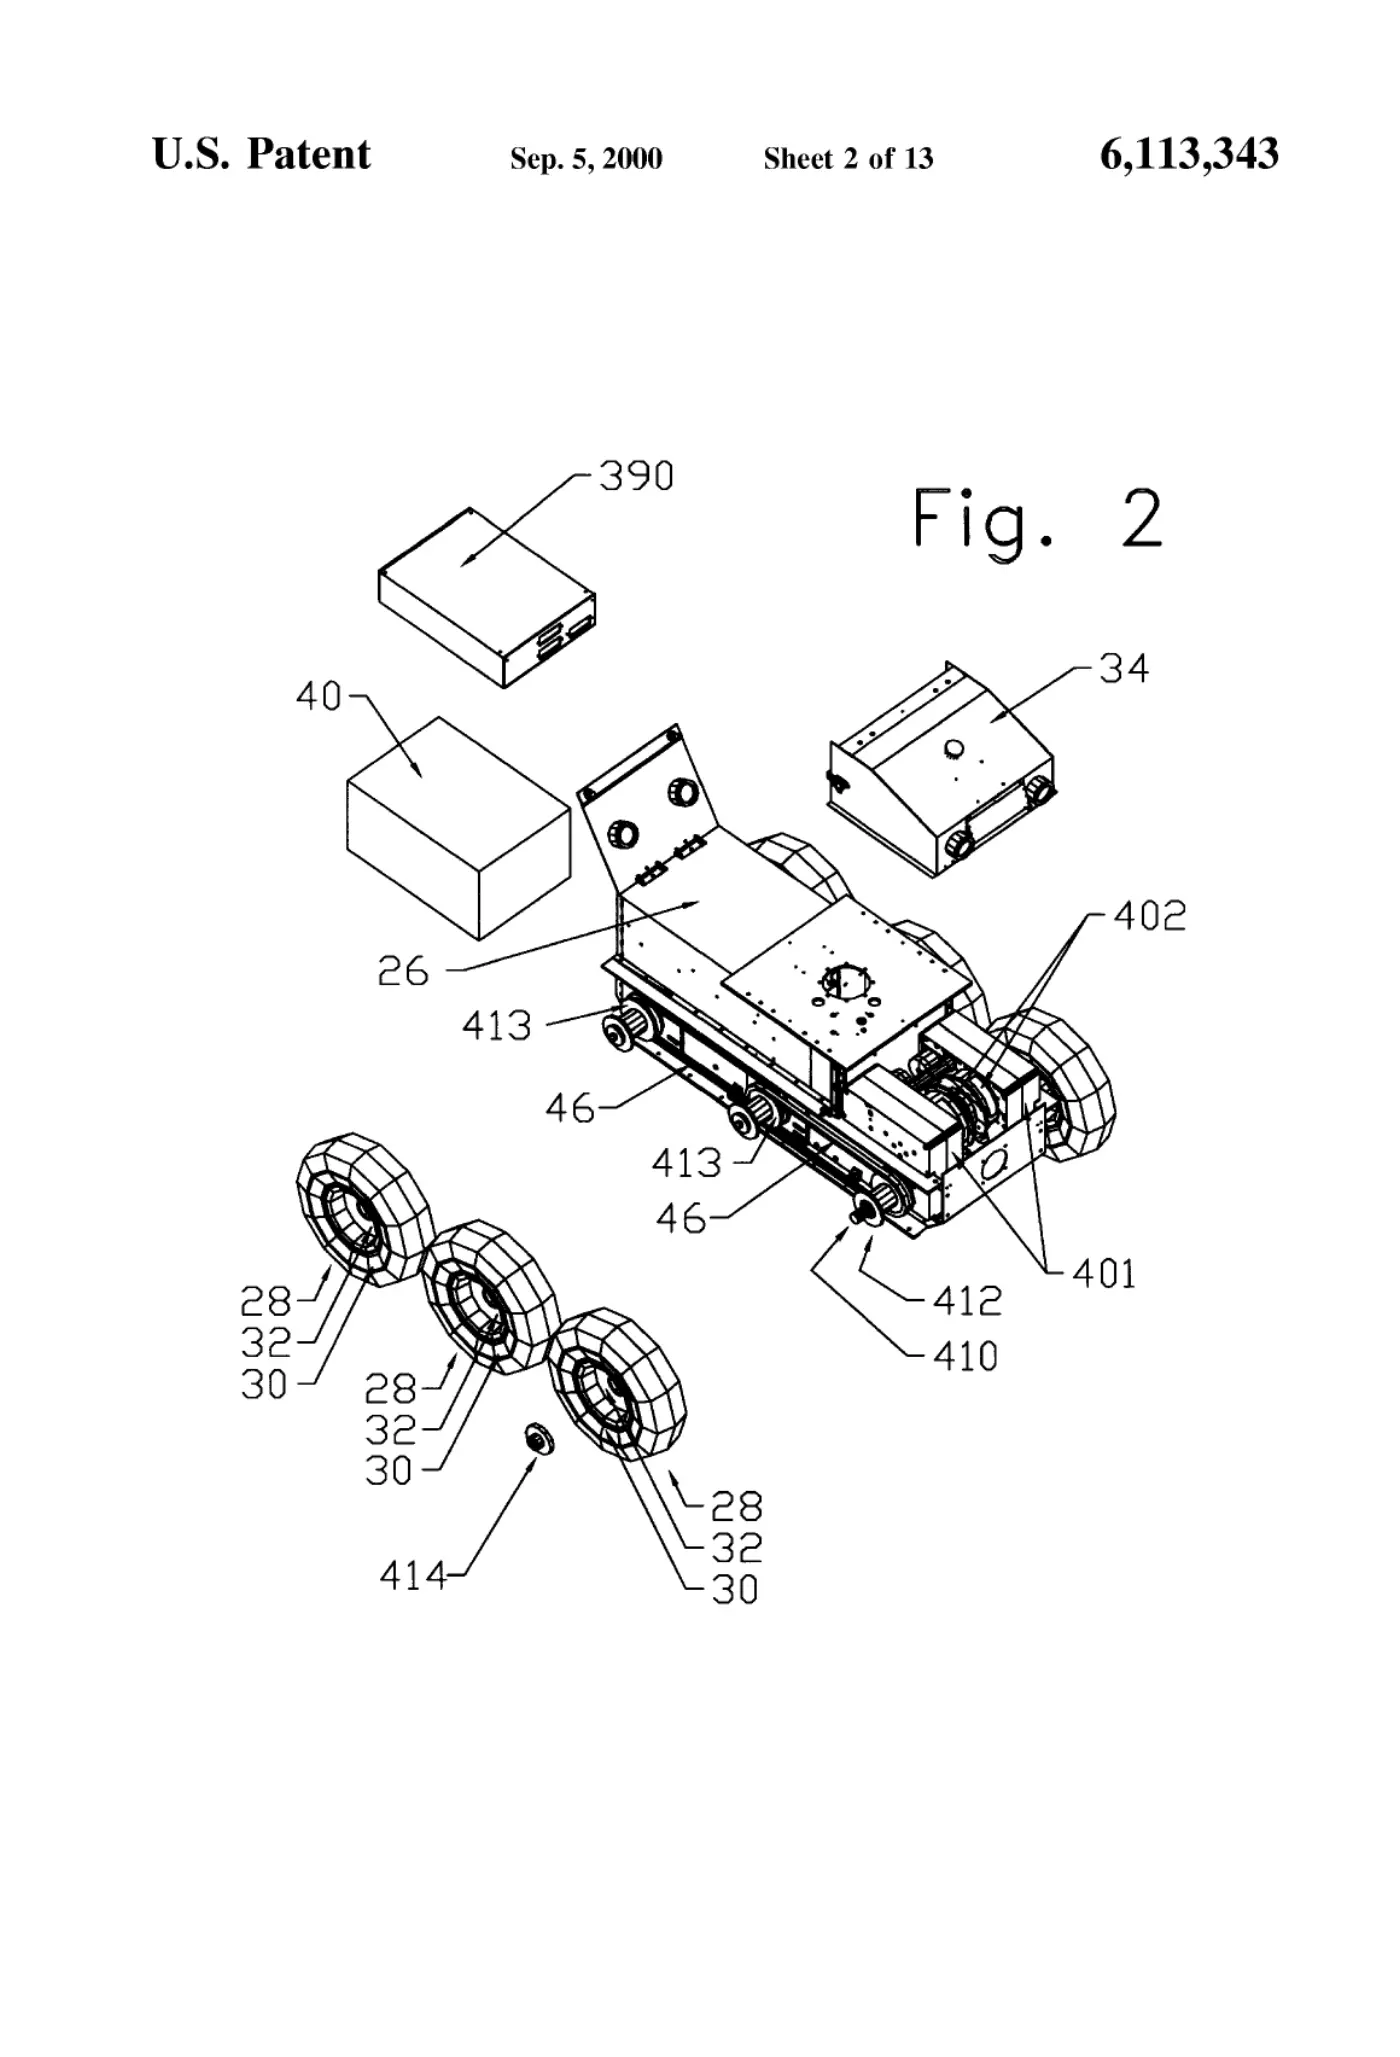
[0002]Sheet 2.
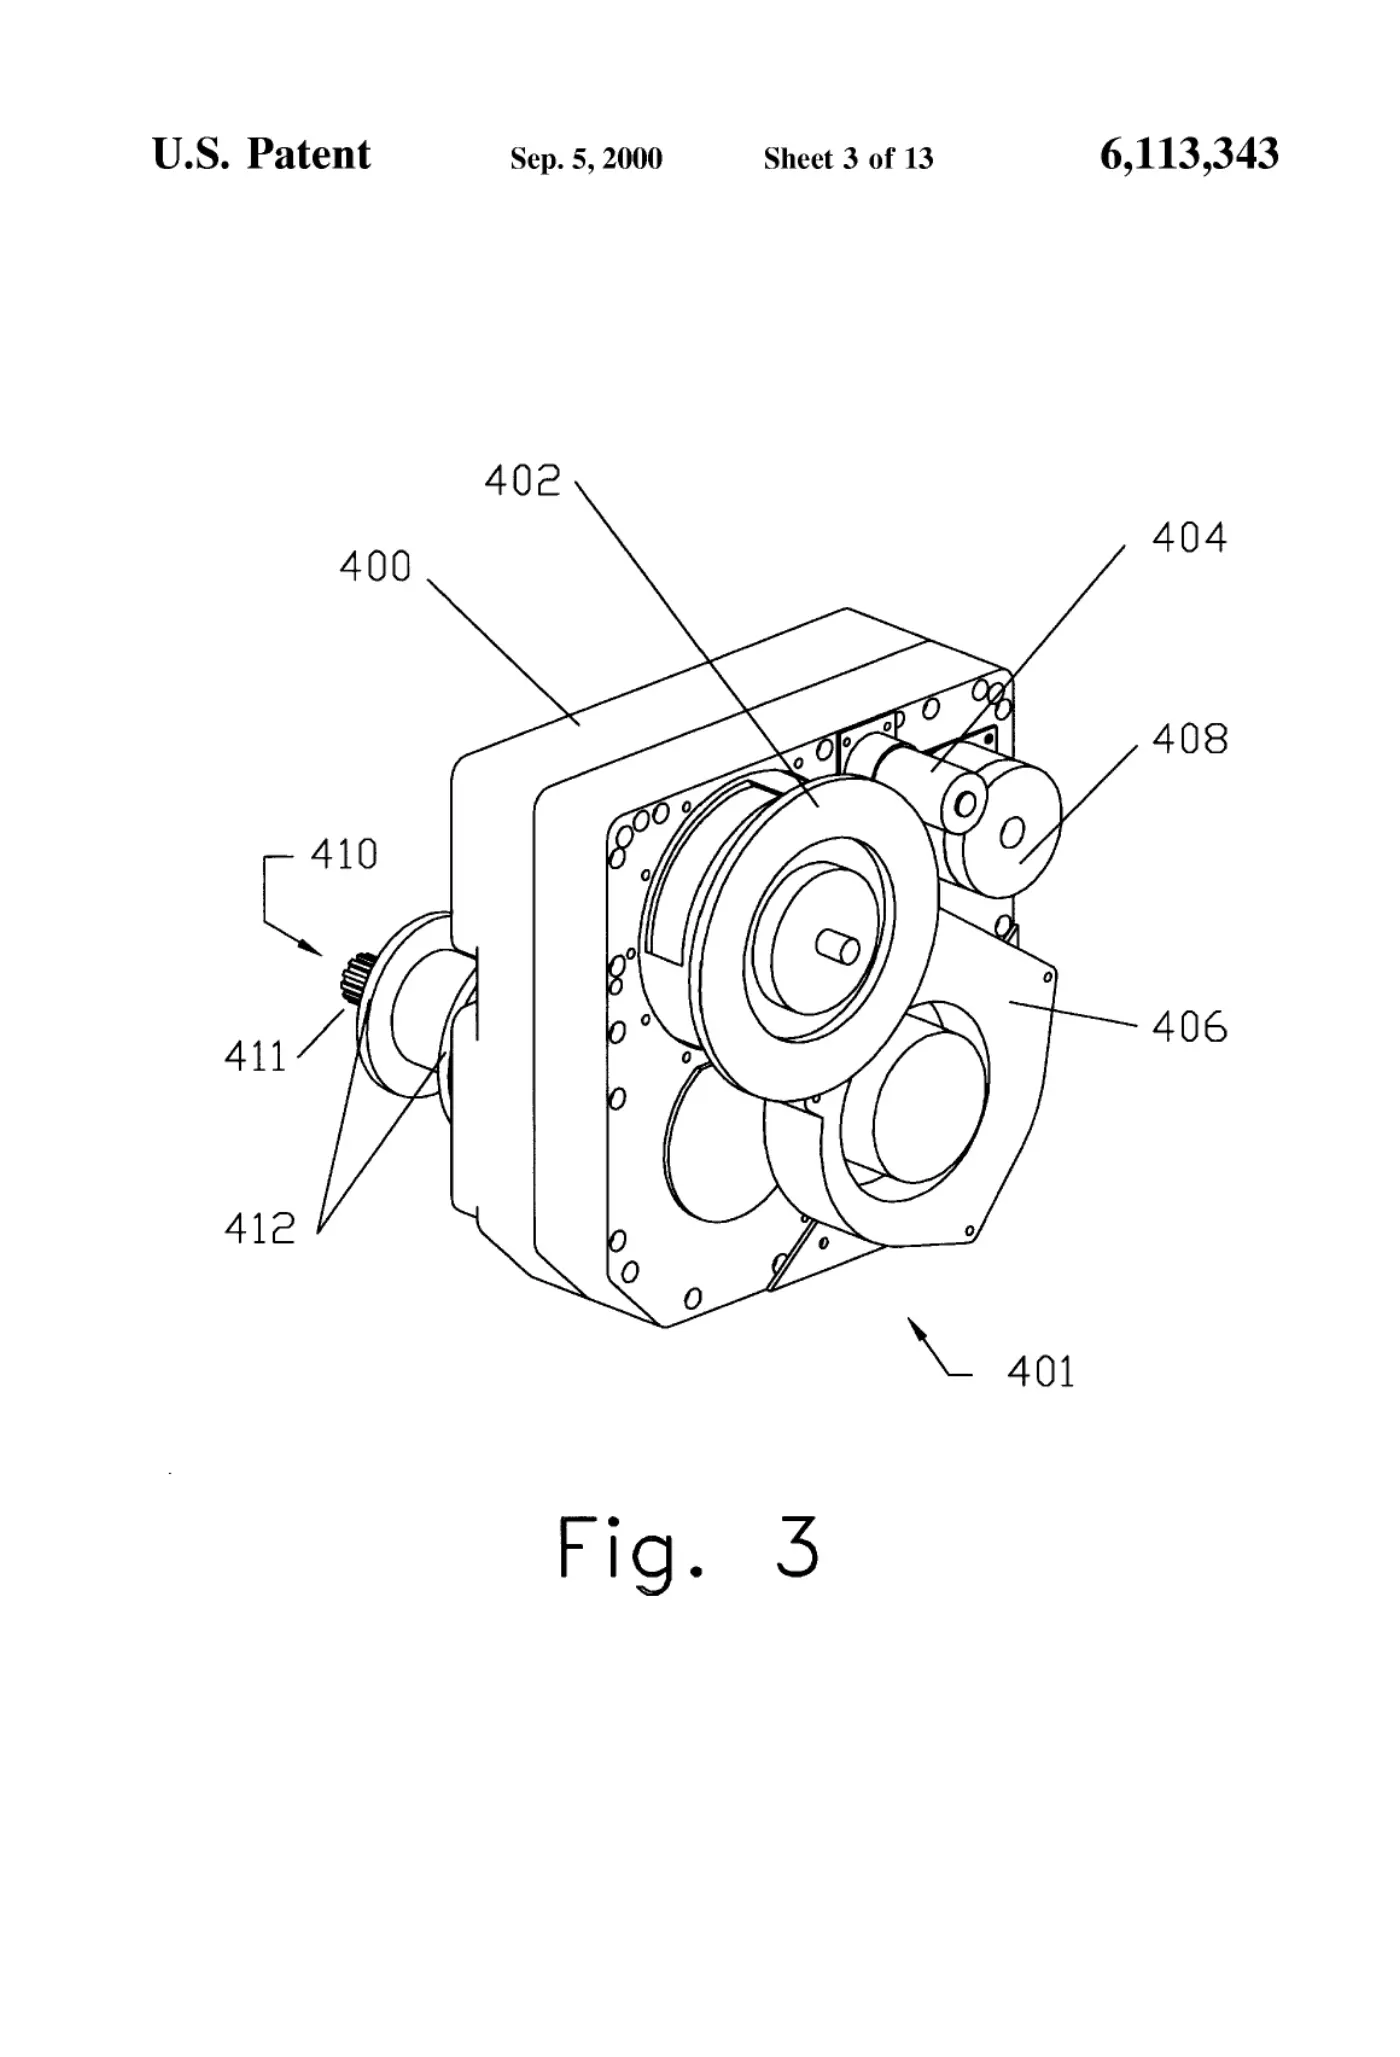
[0003]Sheet 3.
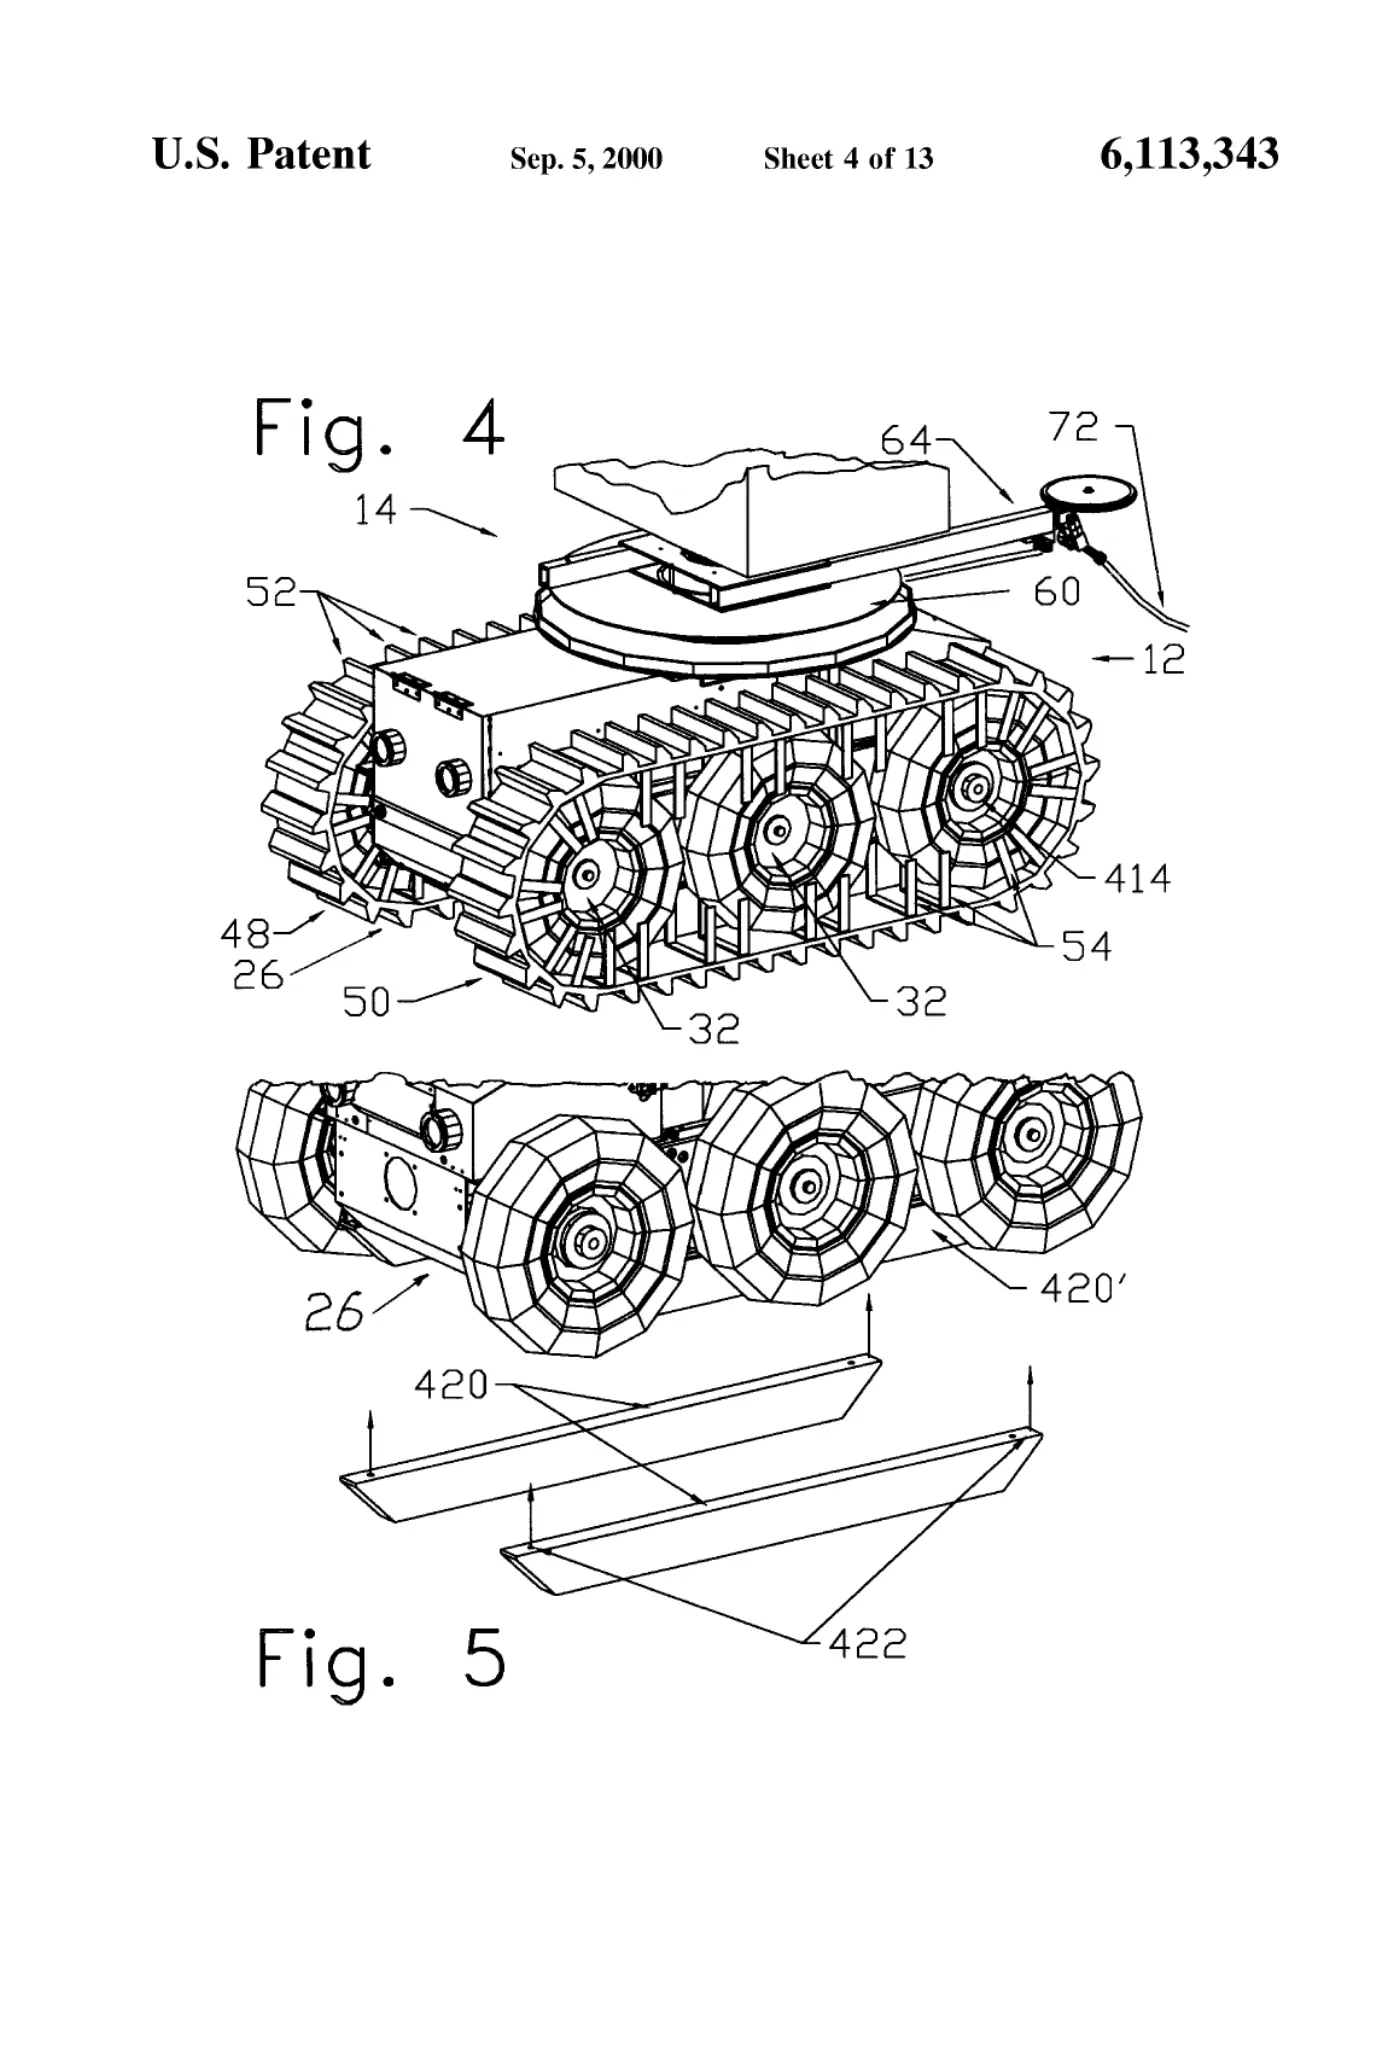
[0004]Sheet 4.
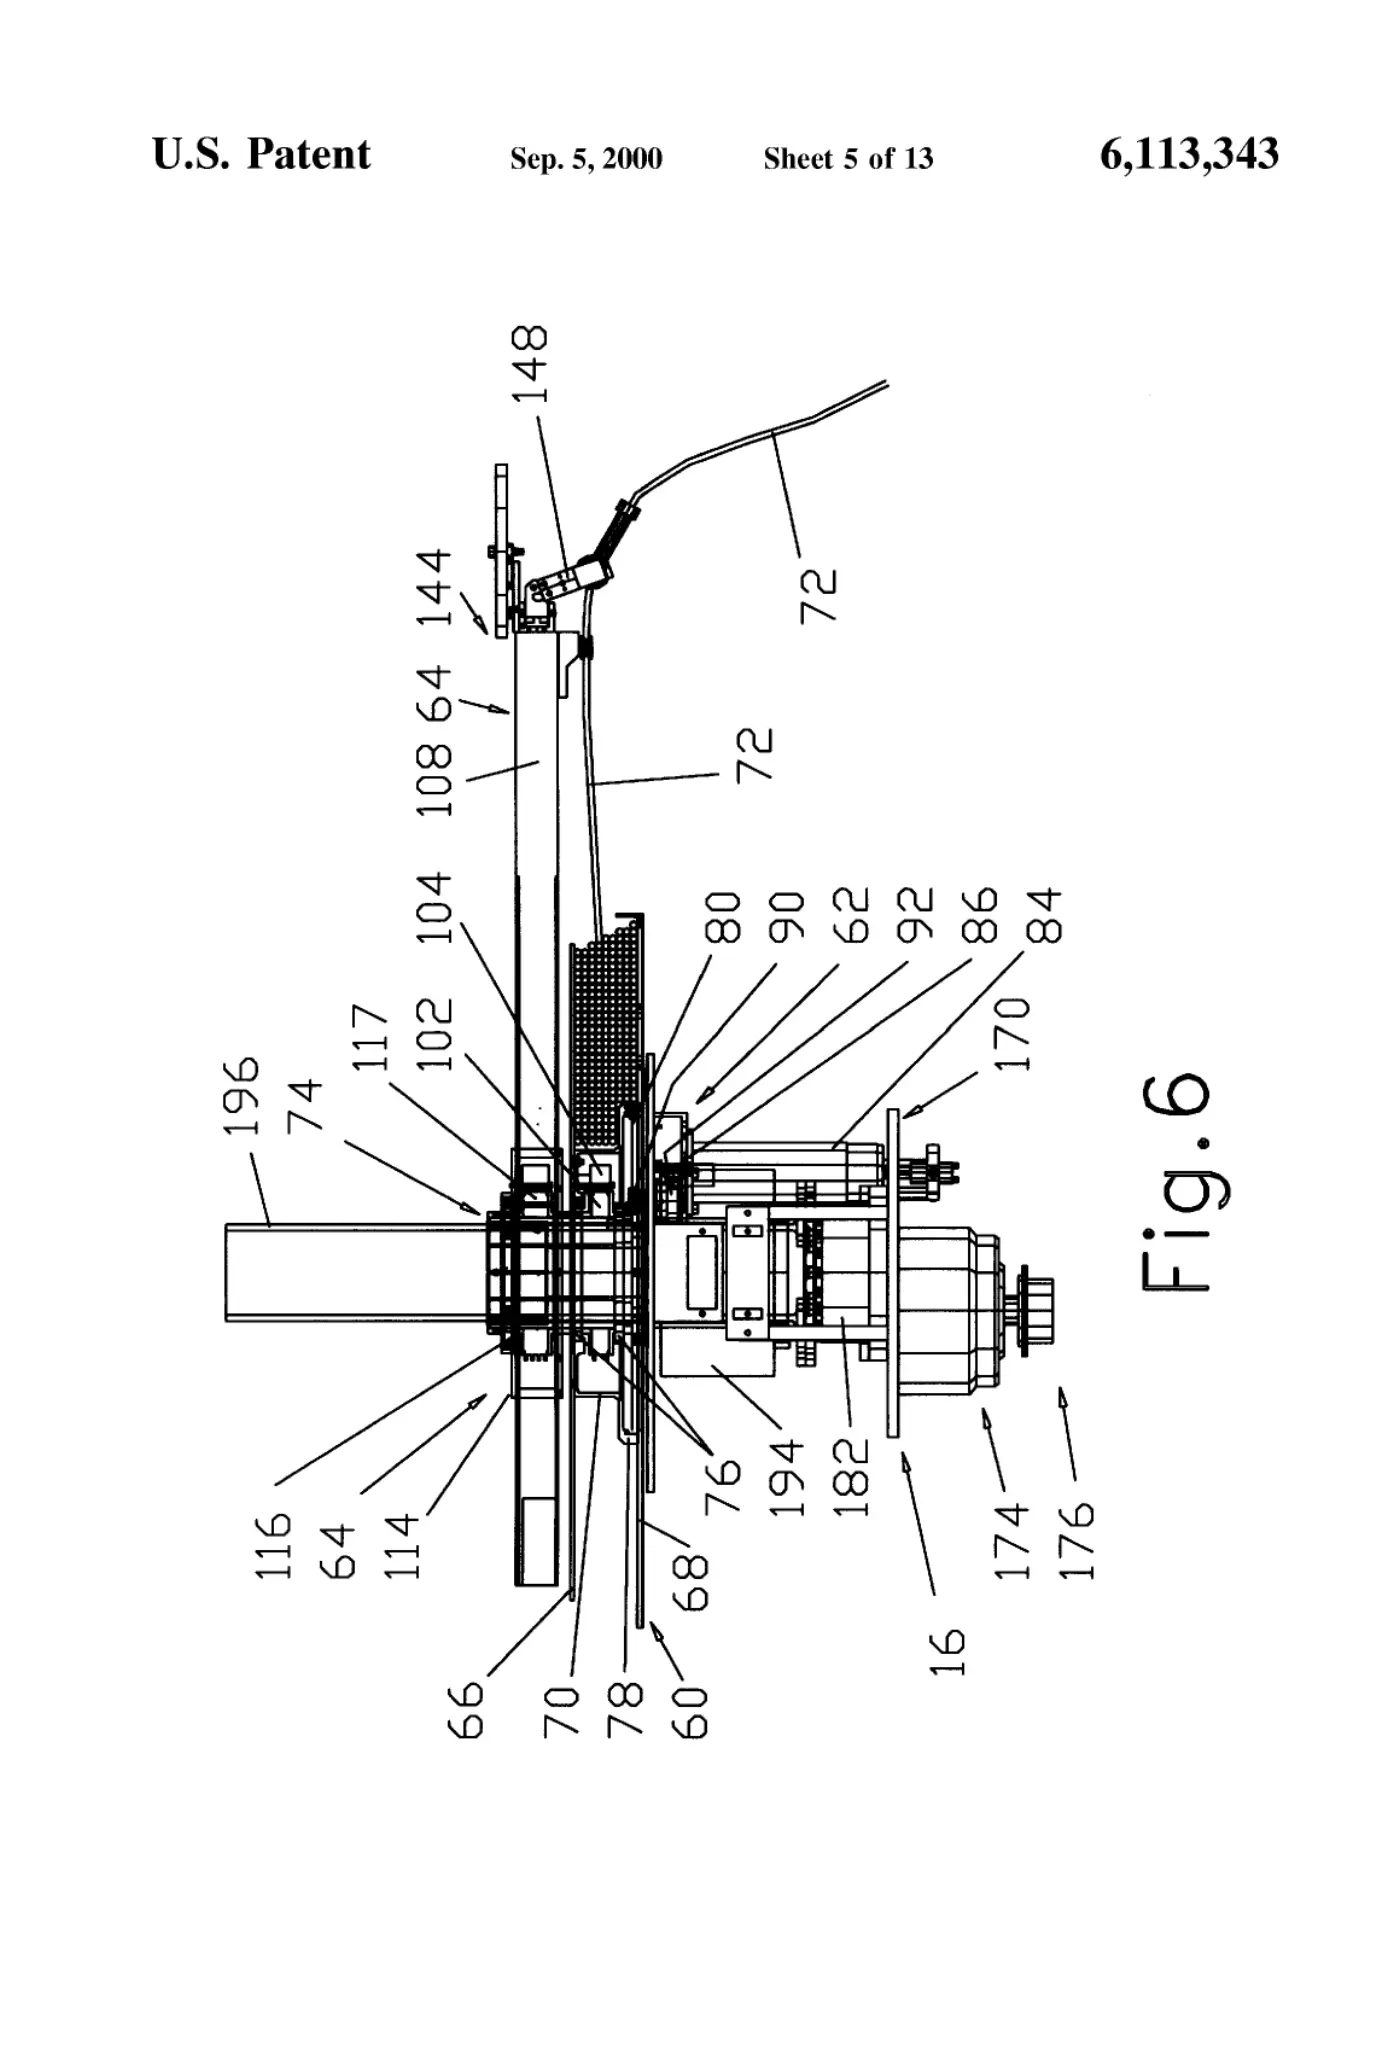
[0005]Sheet 5.
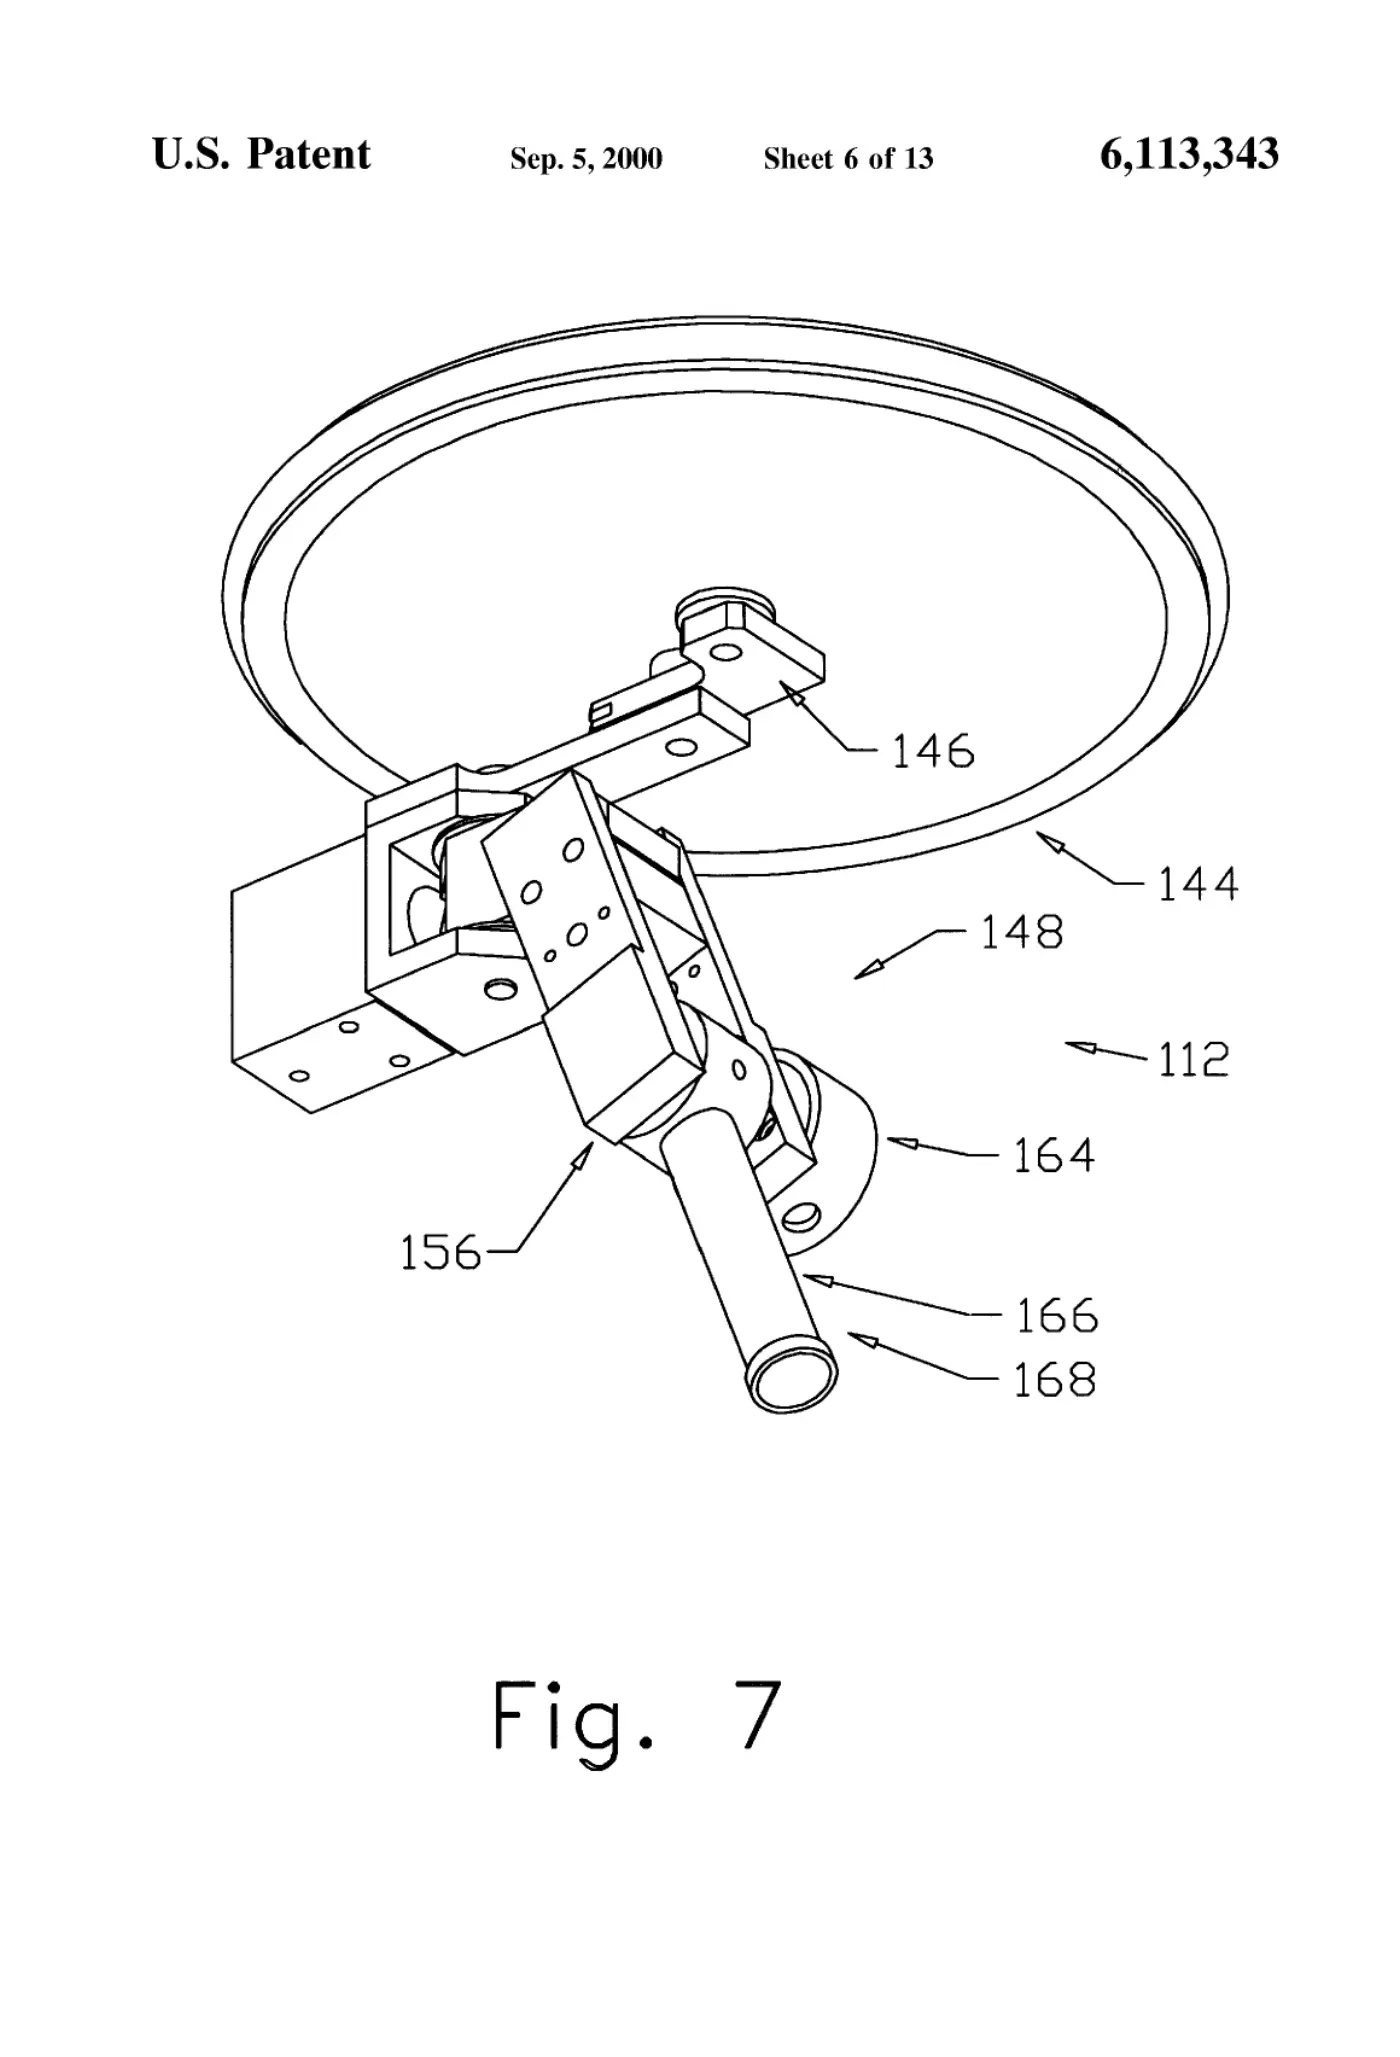
[0006]Sheet 6.
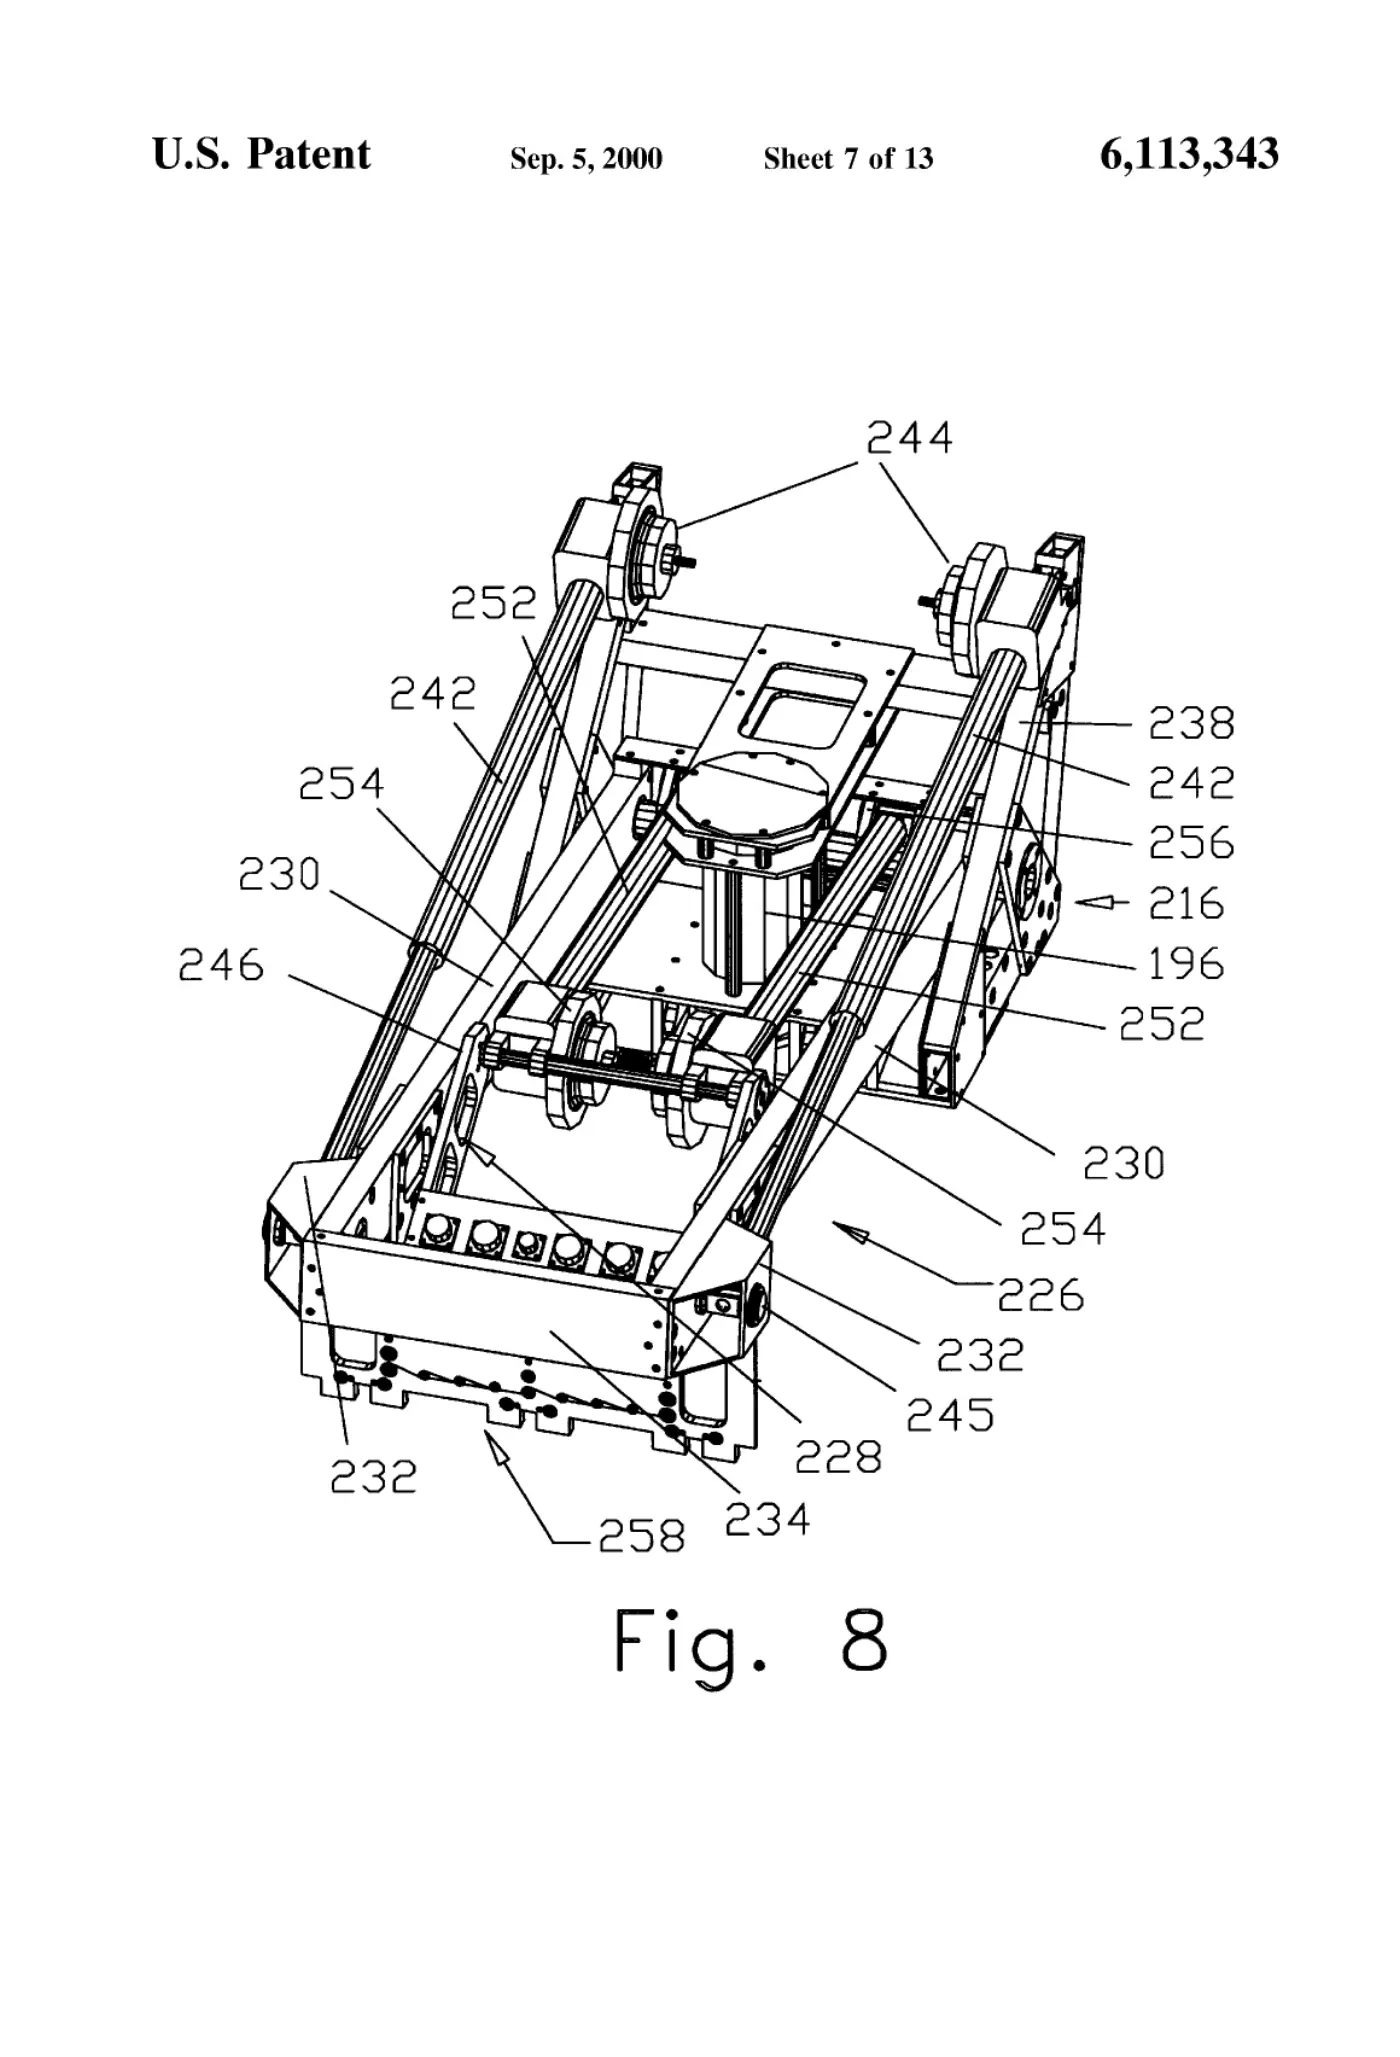
[0007]Sheet 7.
[0008]Sheet 8.
[0009]Sheet 9.
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003134, “Explosives disposal robot,” published September 15, 2026 at 19:36:08 UTC, https://opentechnical.org/p/OT-2026-000003134.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.