OT-2026-000003141
Operation control device for three-joint excavator
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003141
- Classification
- Tools & Tooling › Clamping Tools
- Original source
- US-6101437-A, the United States Patent and Trademark Office, 8 August 2000
- Document SHA-256
- 723e45dd8f8c802884c9d57967c3ddd0ba4bb40827bb13aa9d6308464c0ea19d
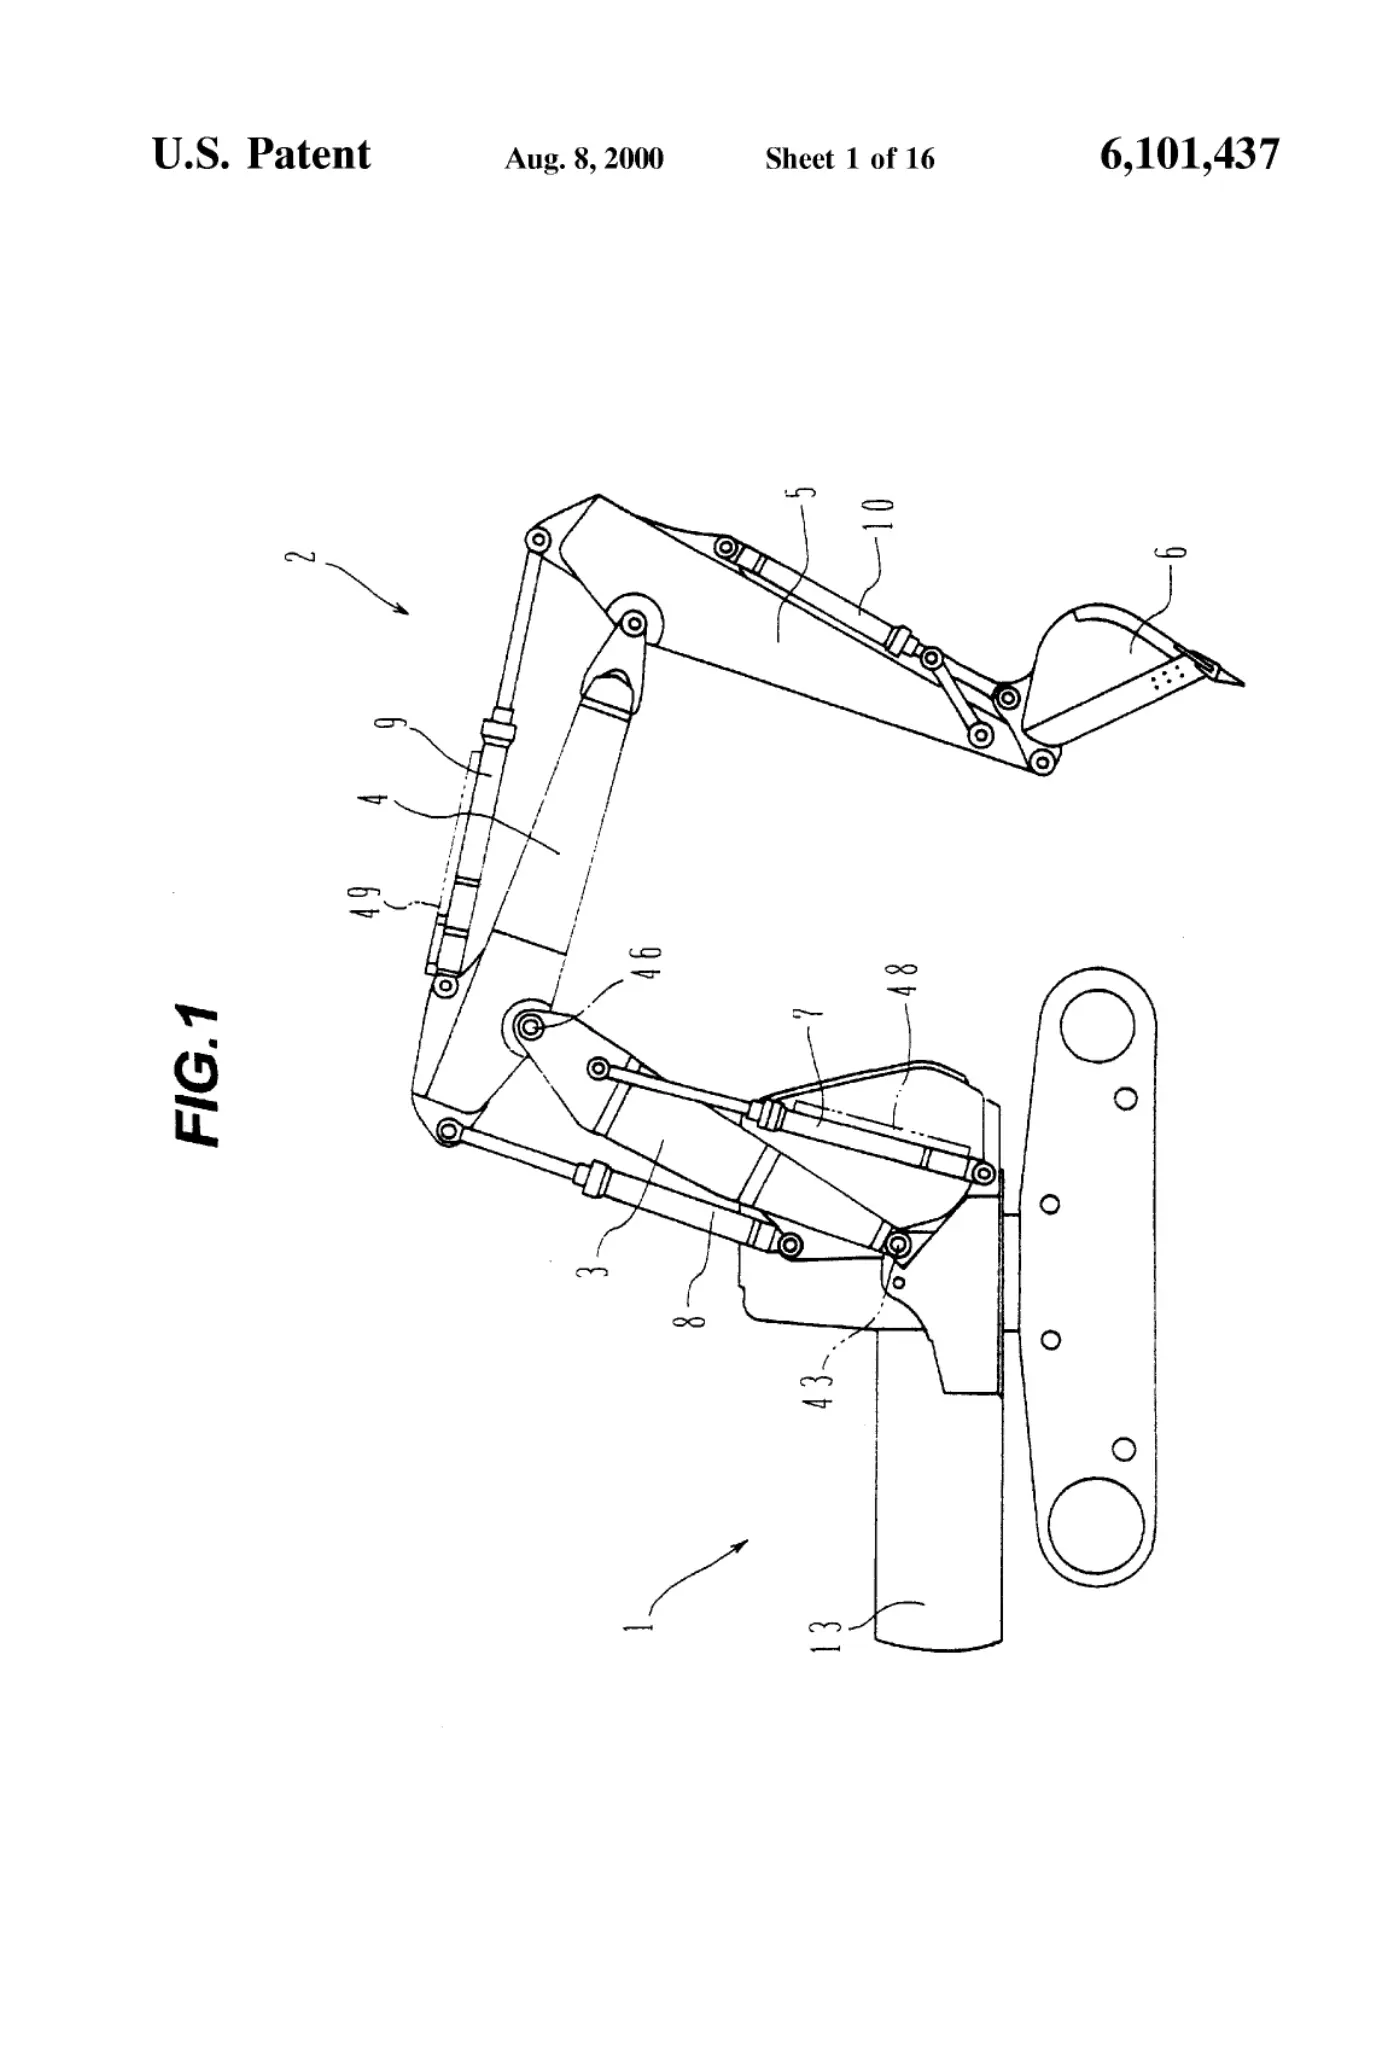
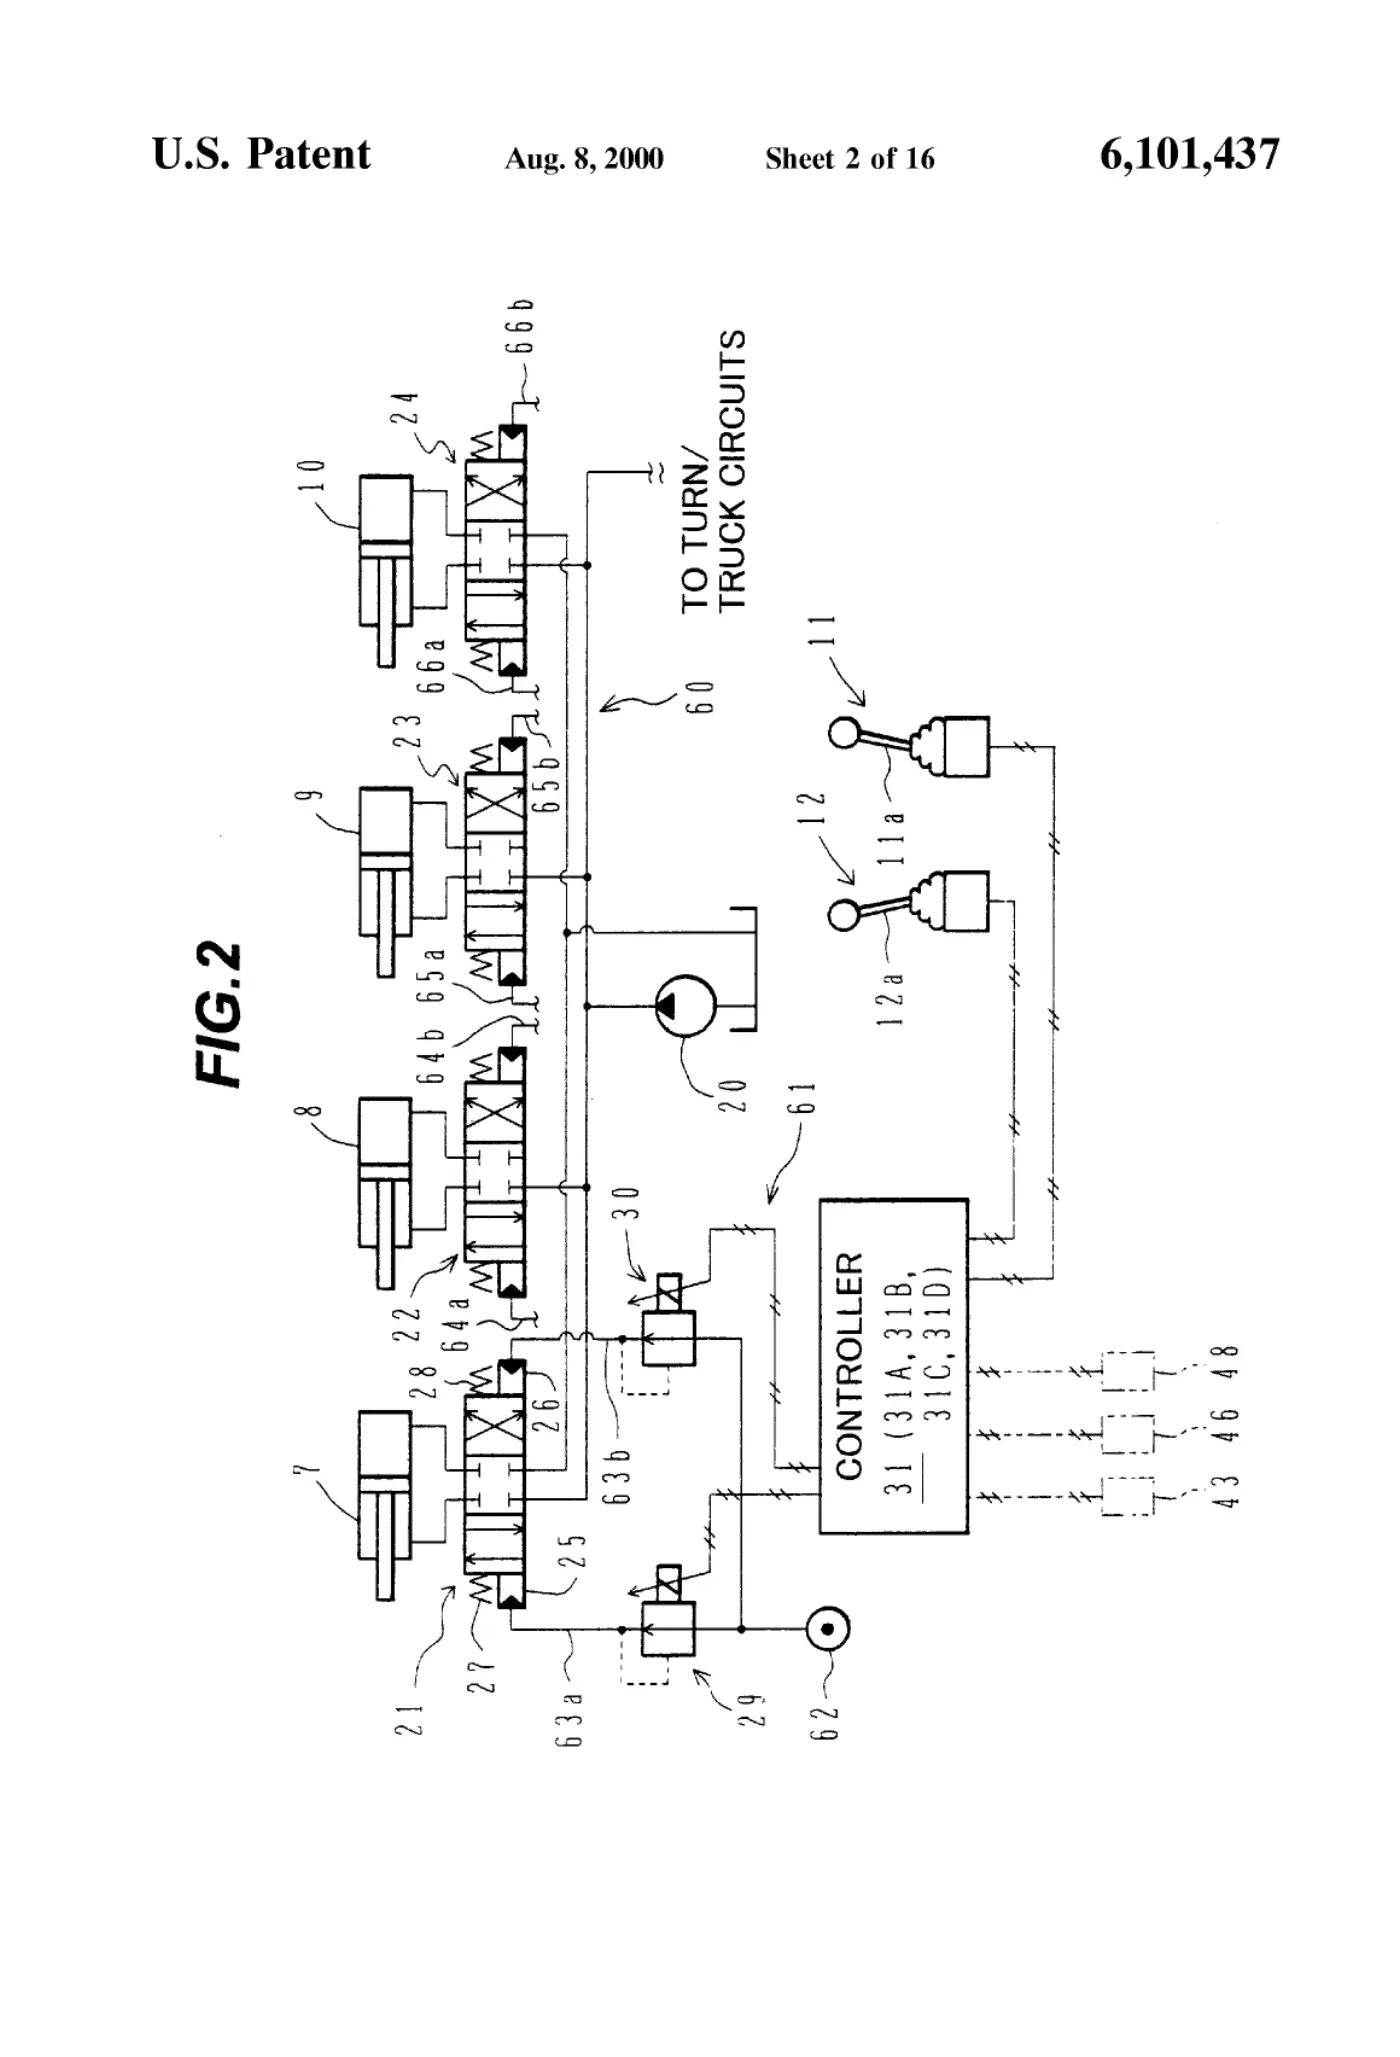
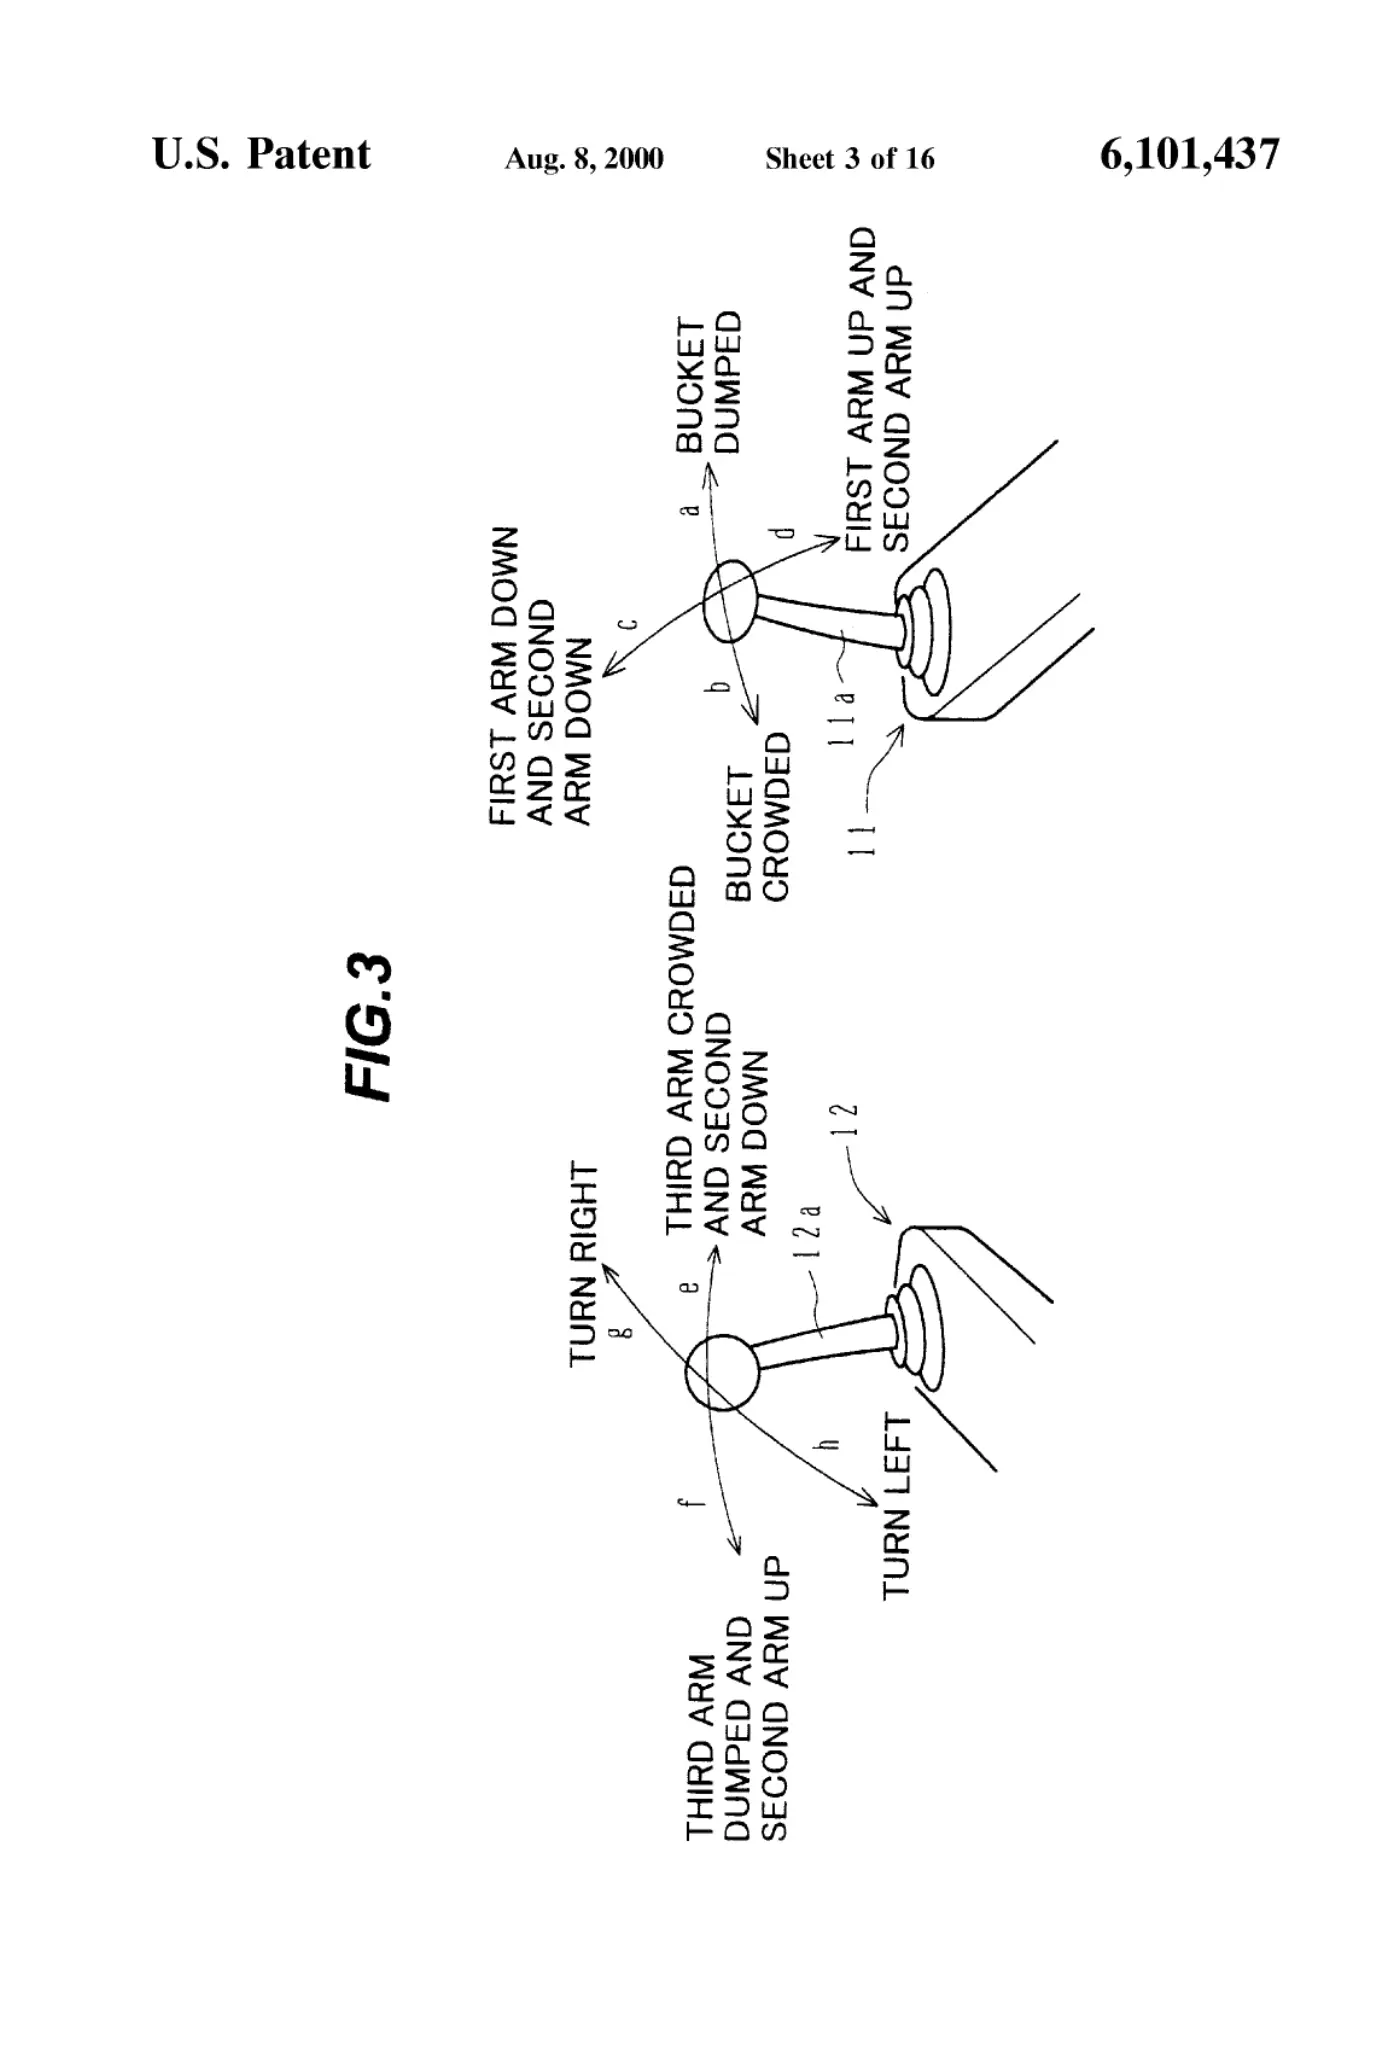
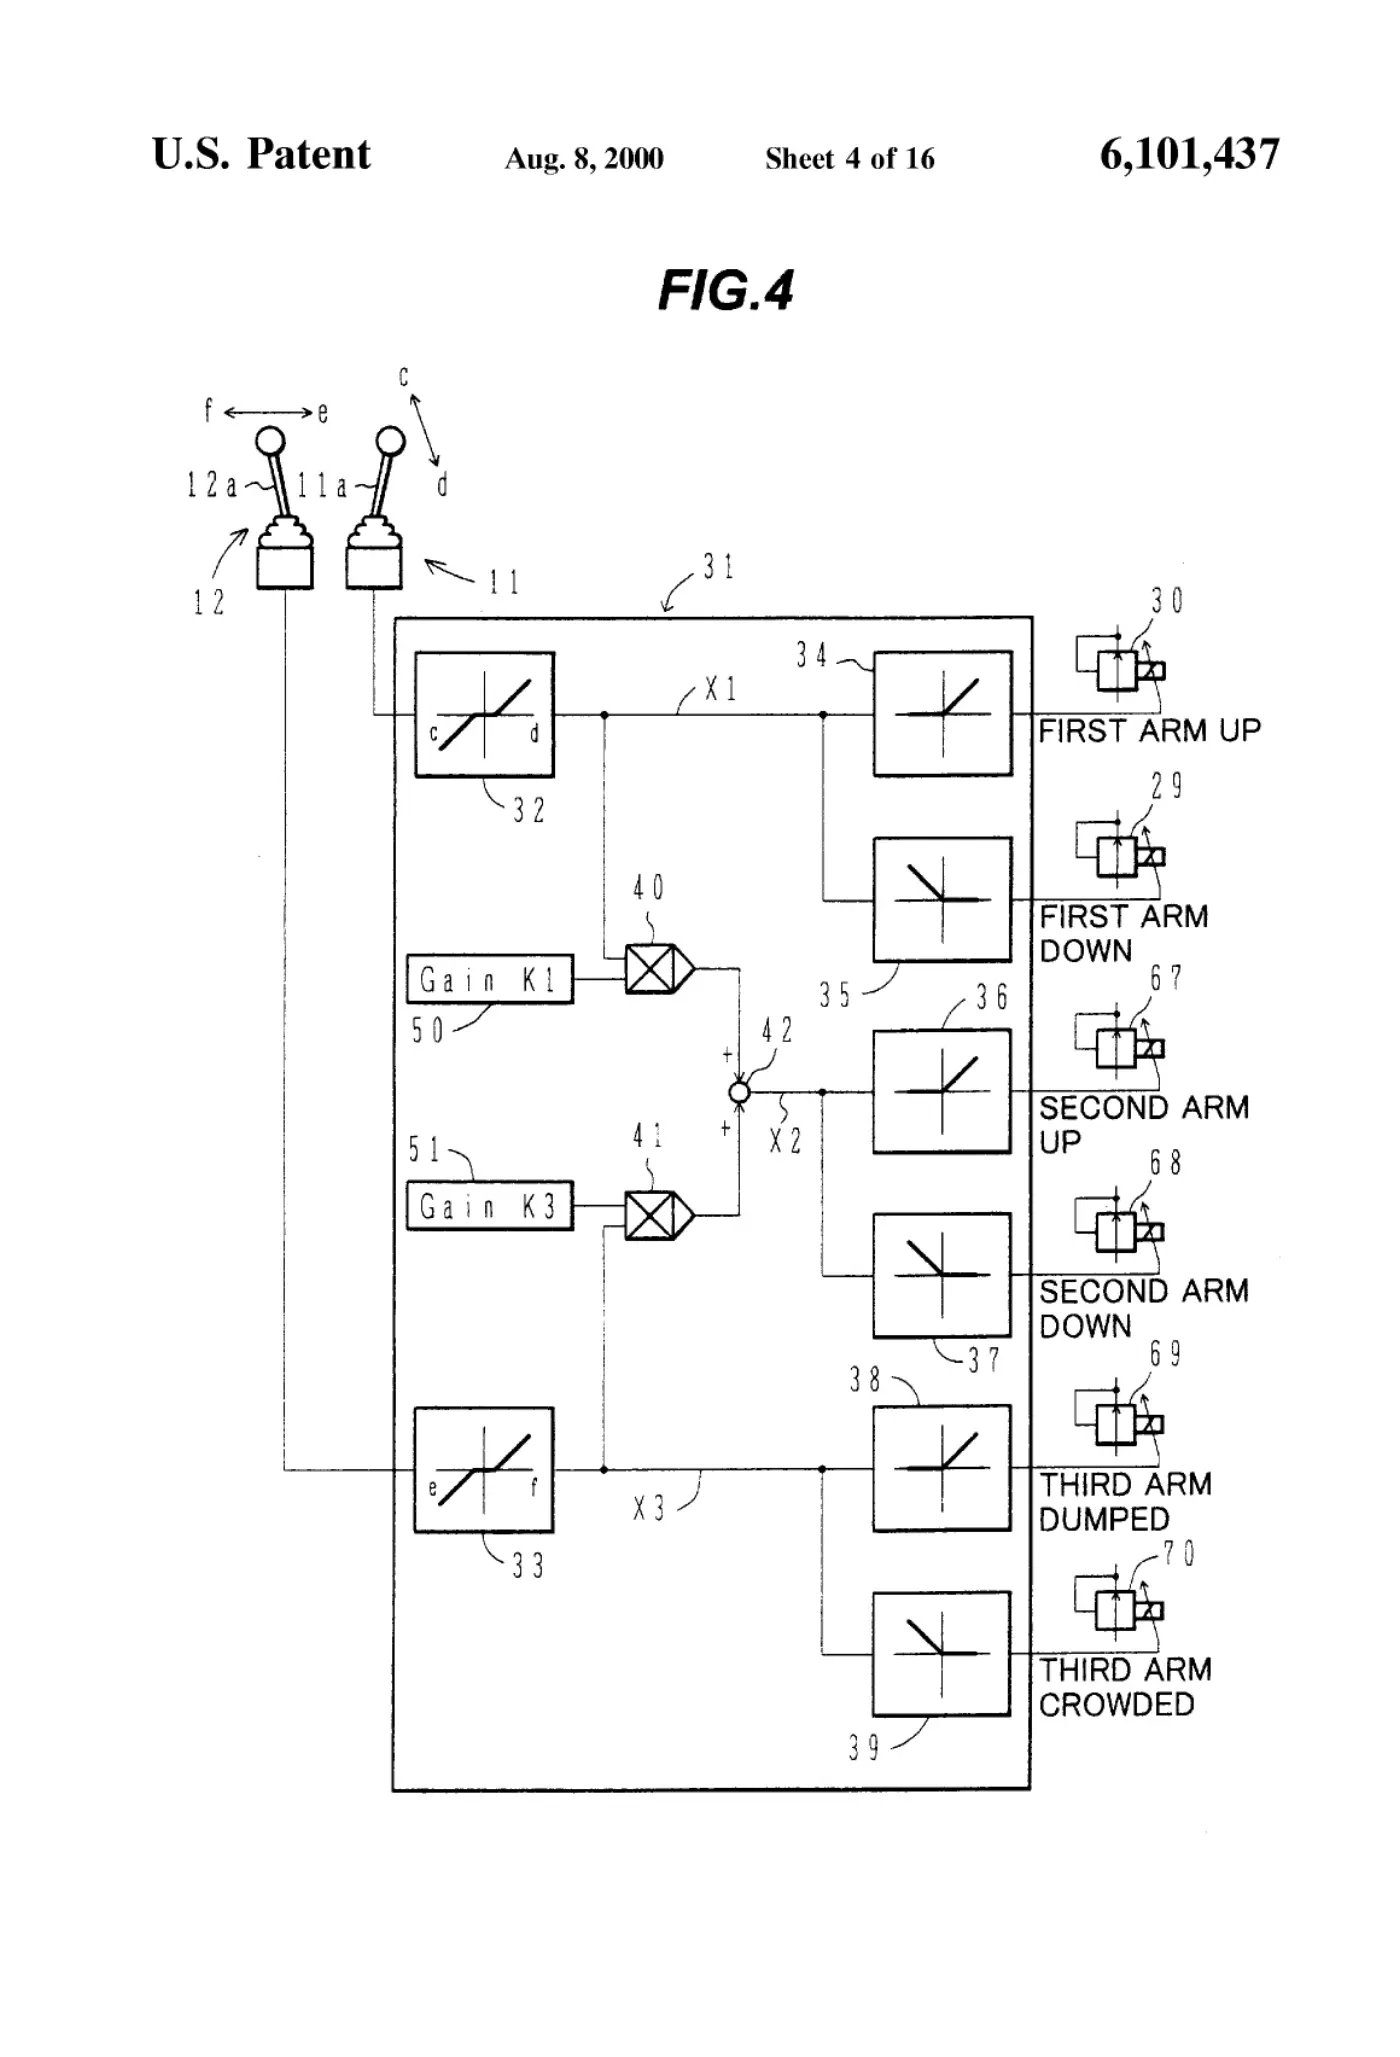
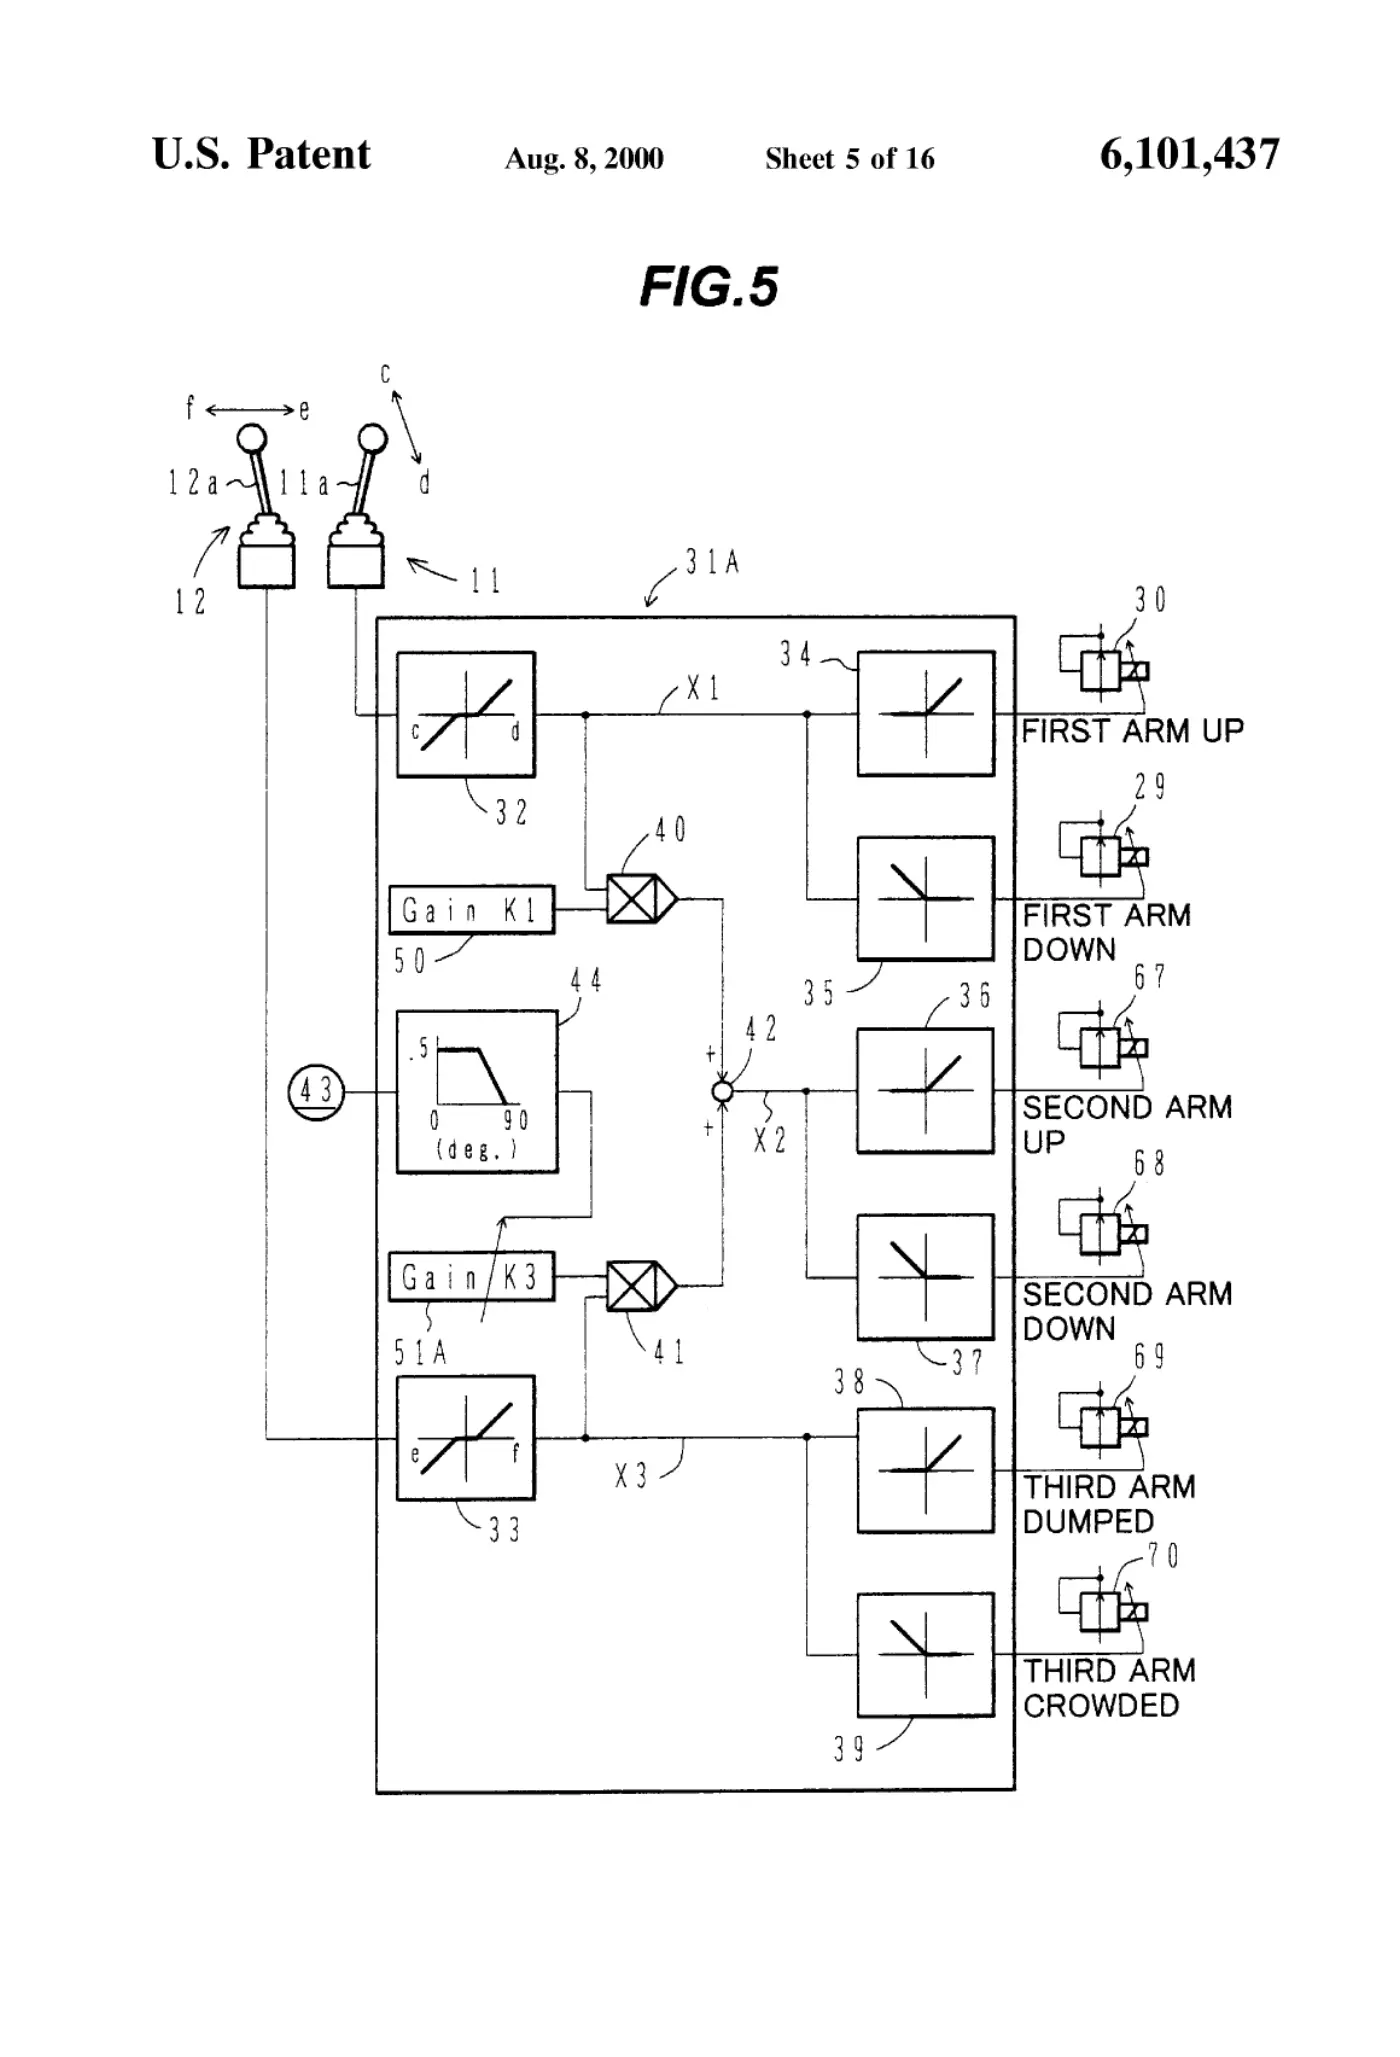
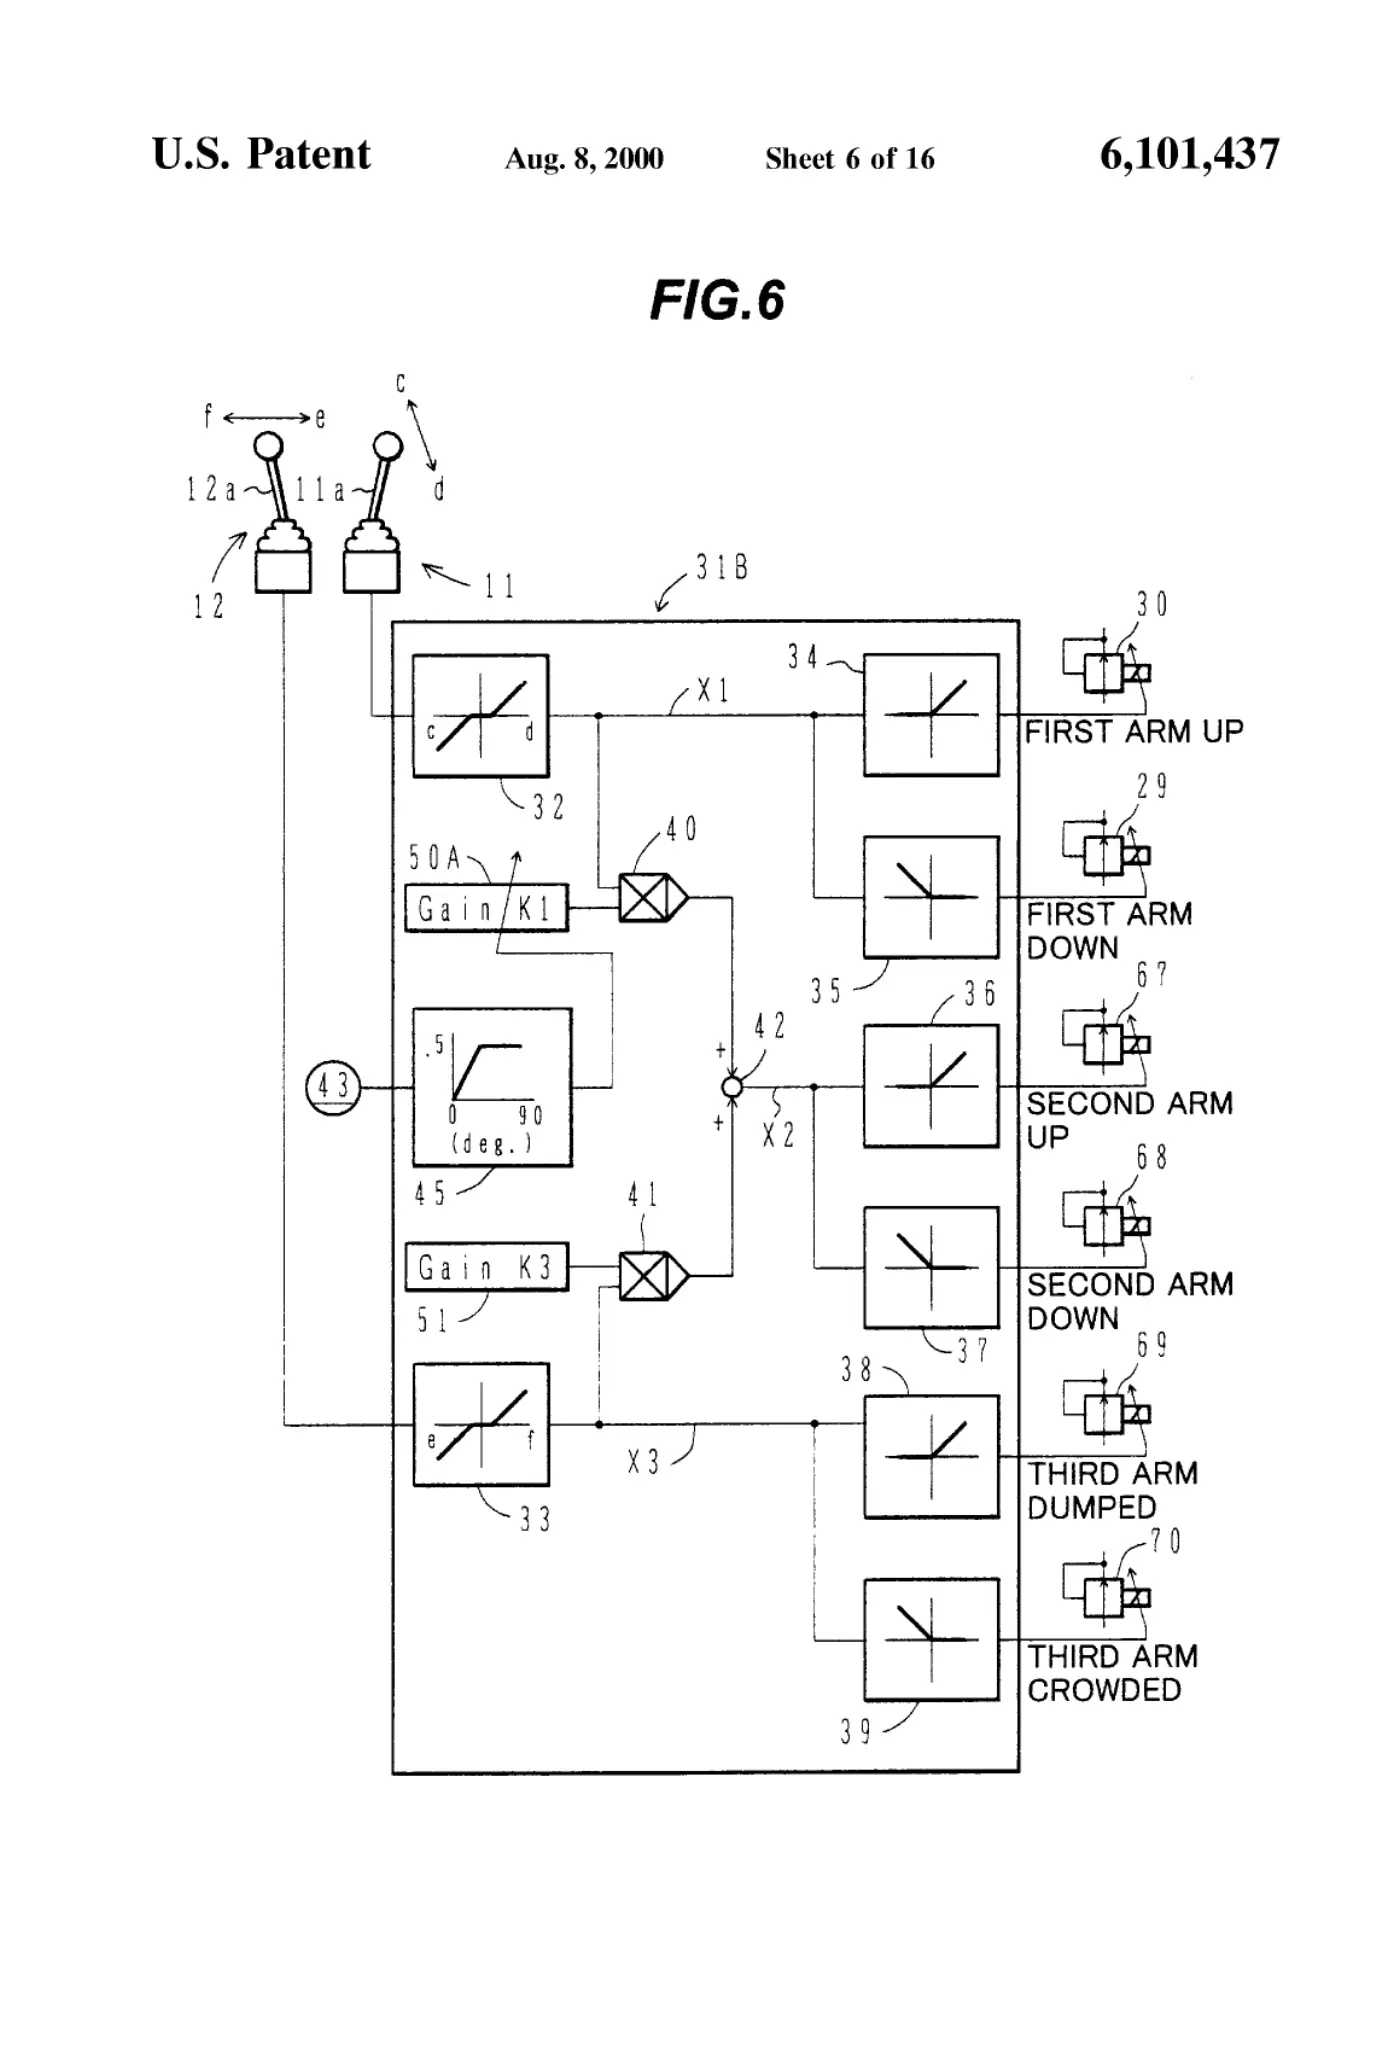
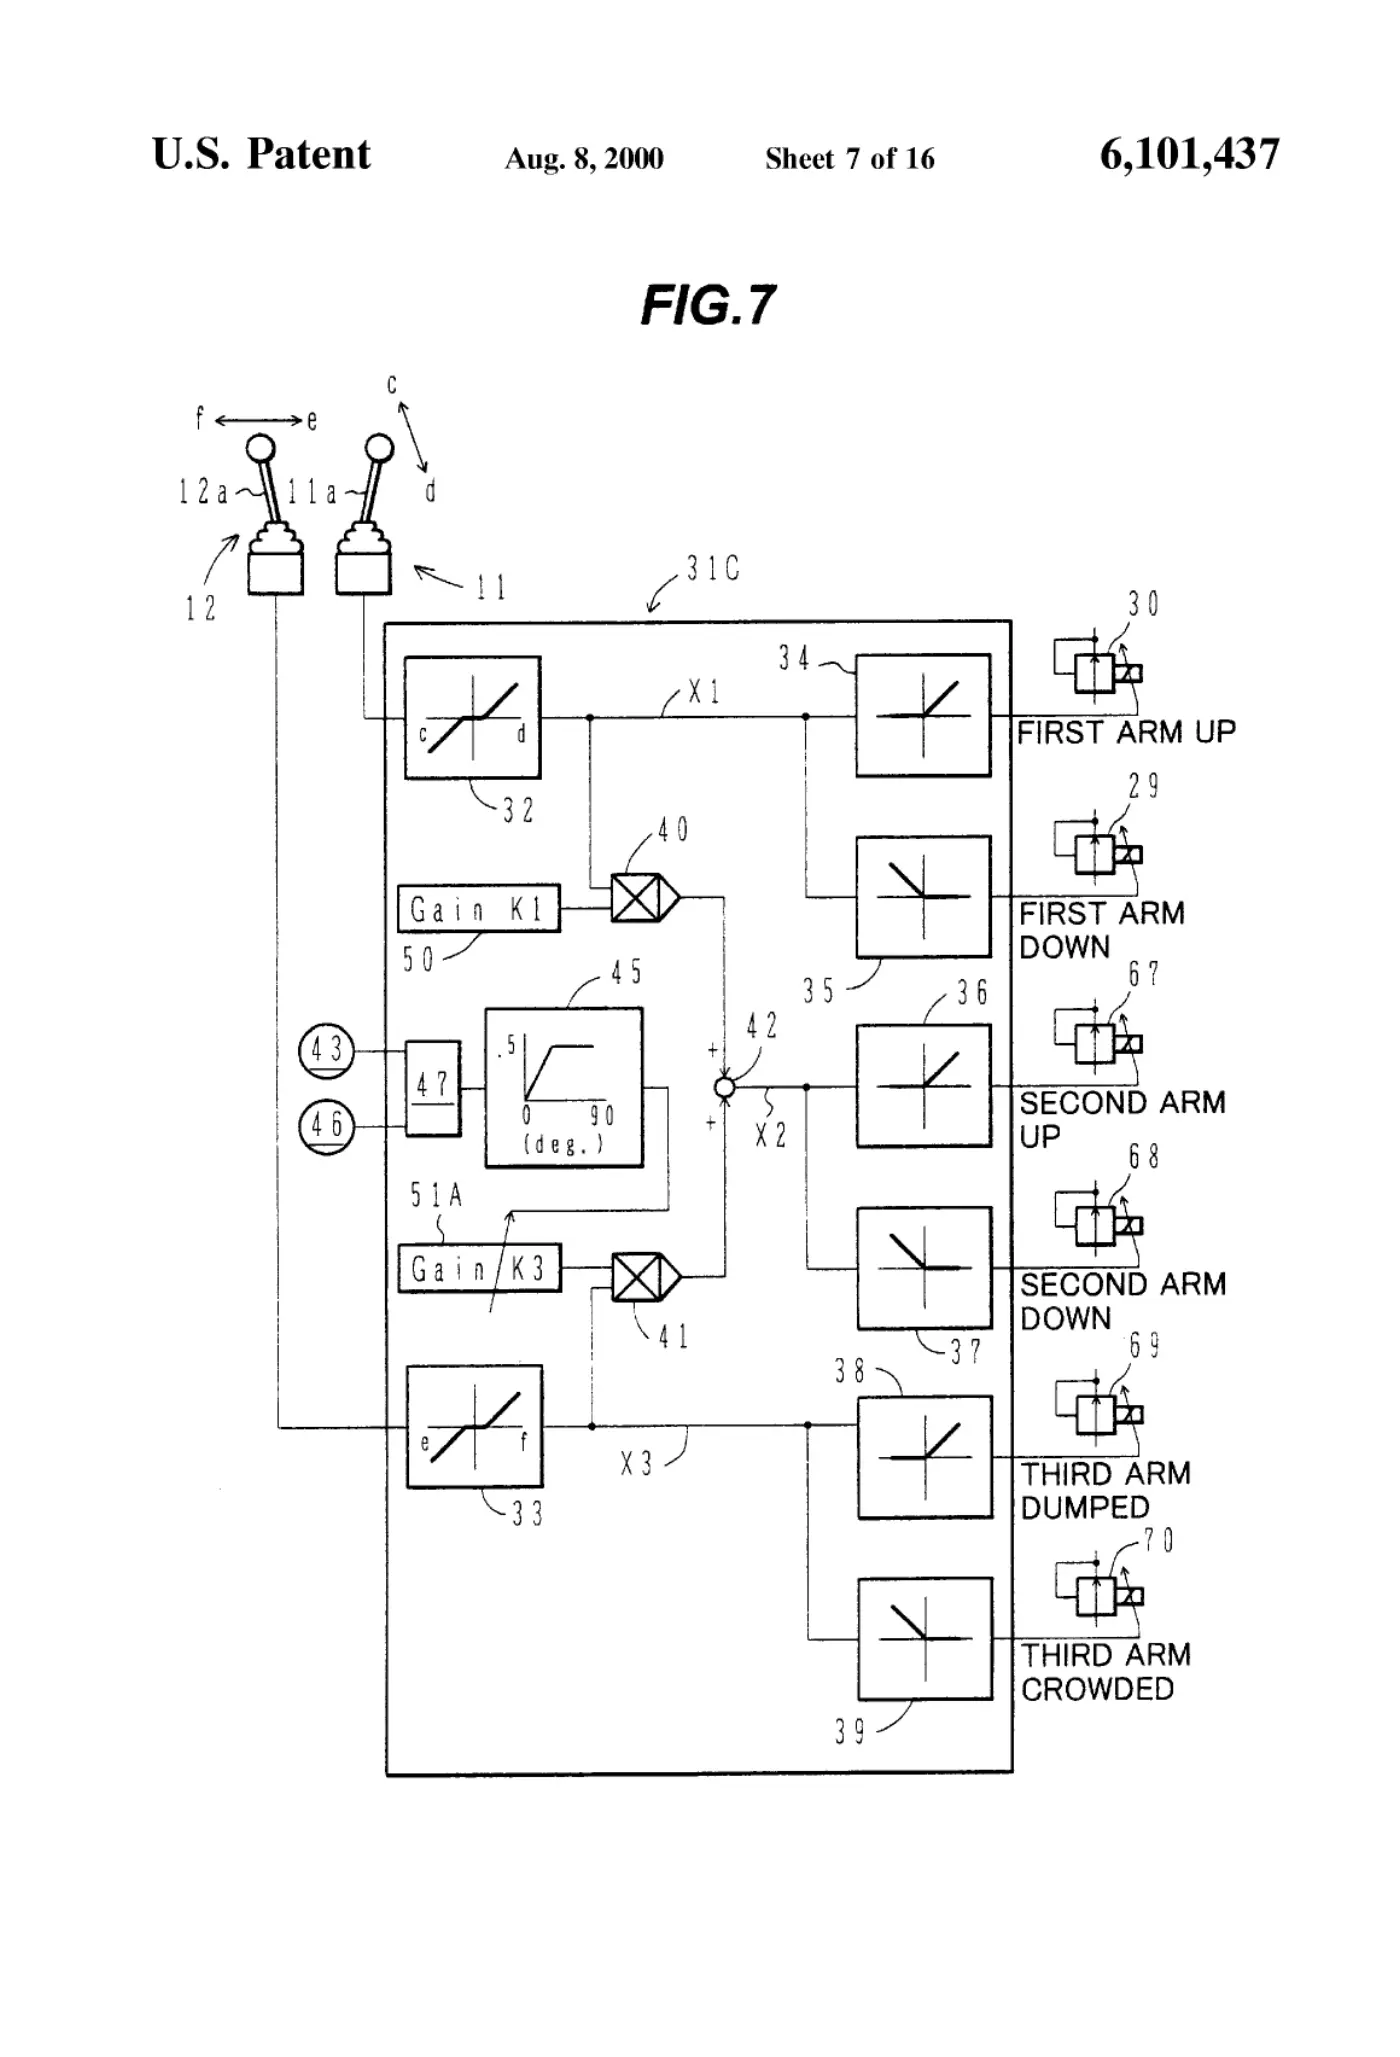
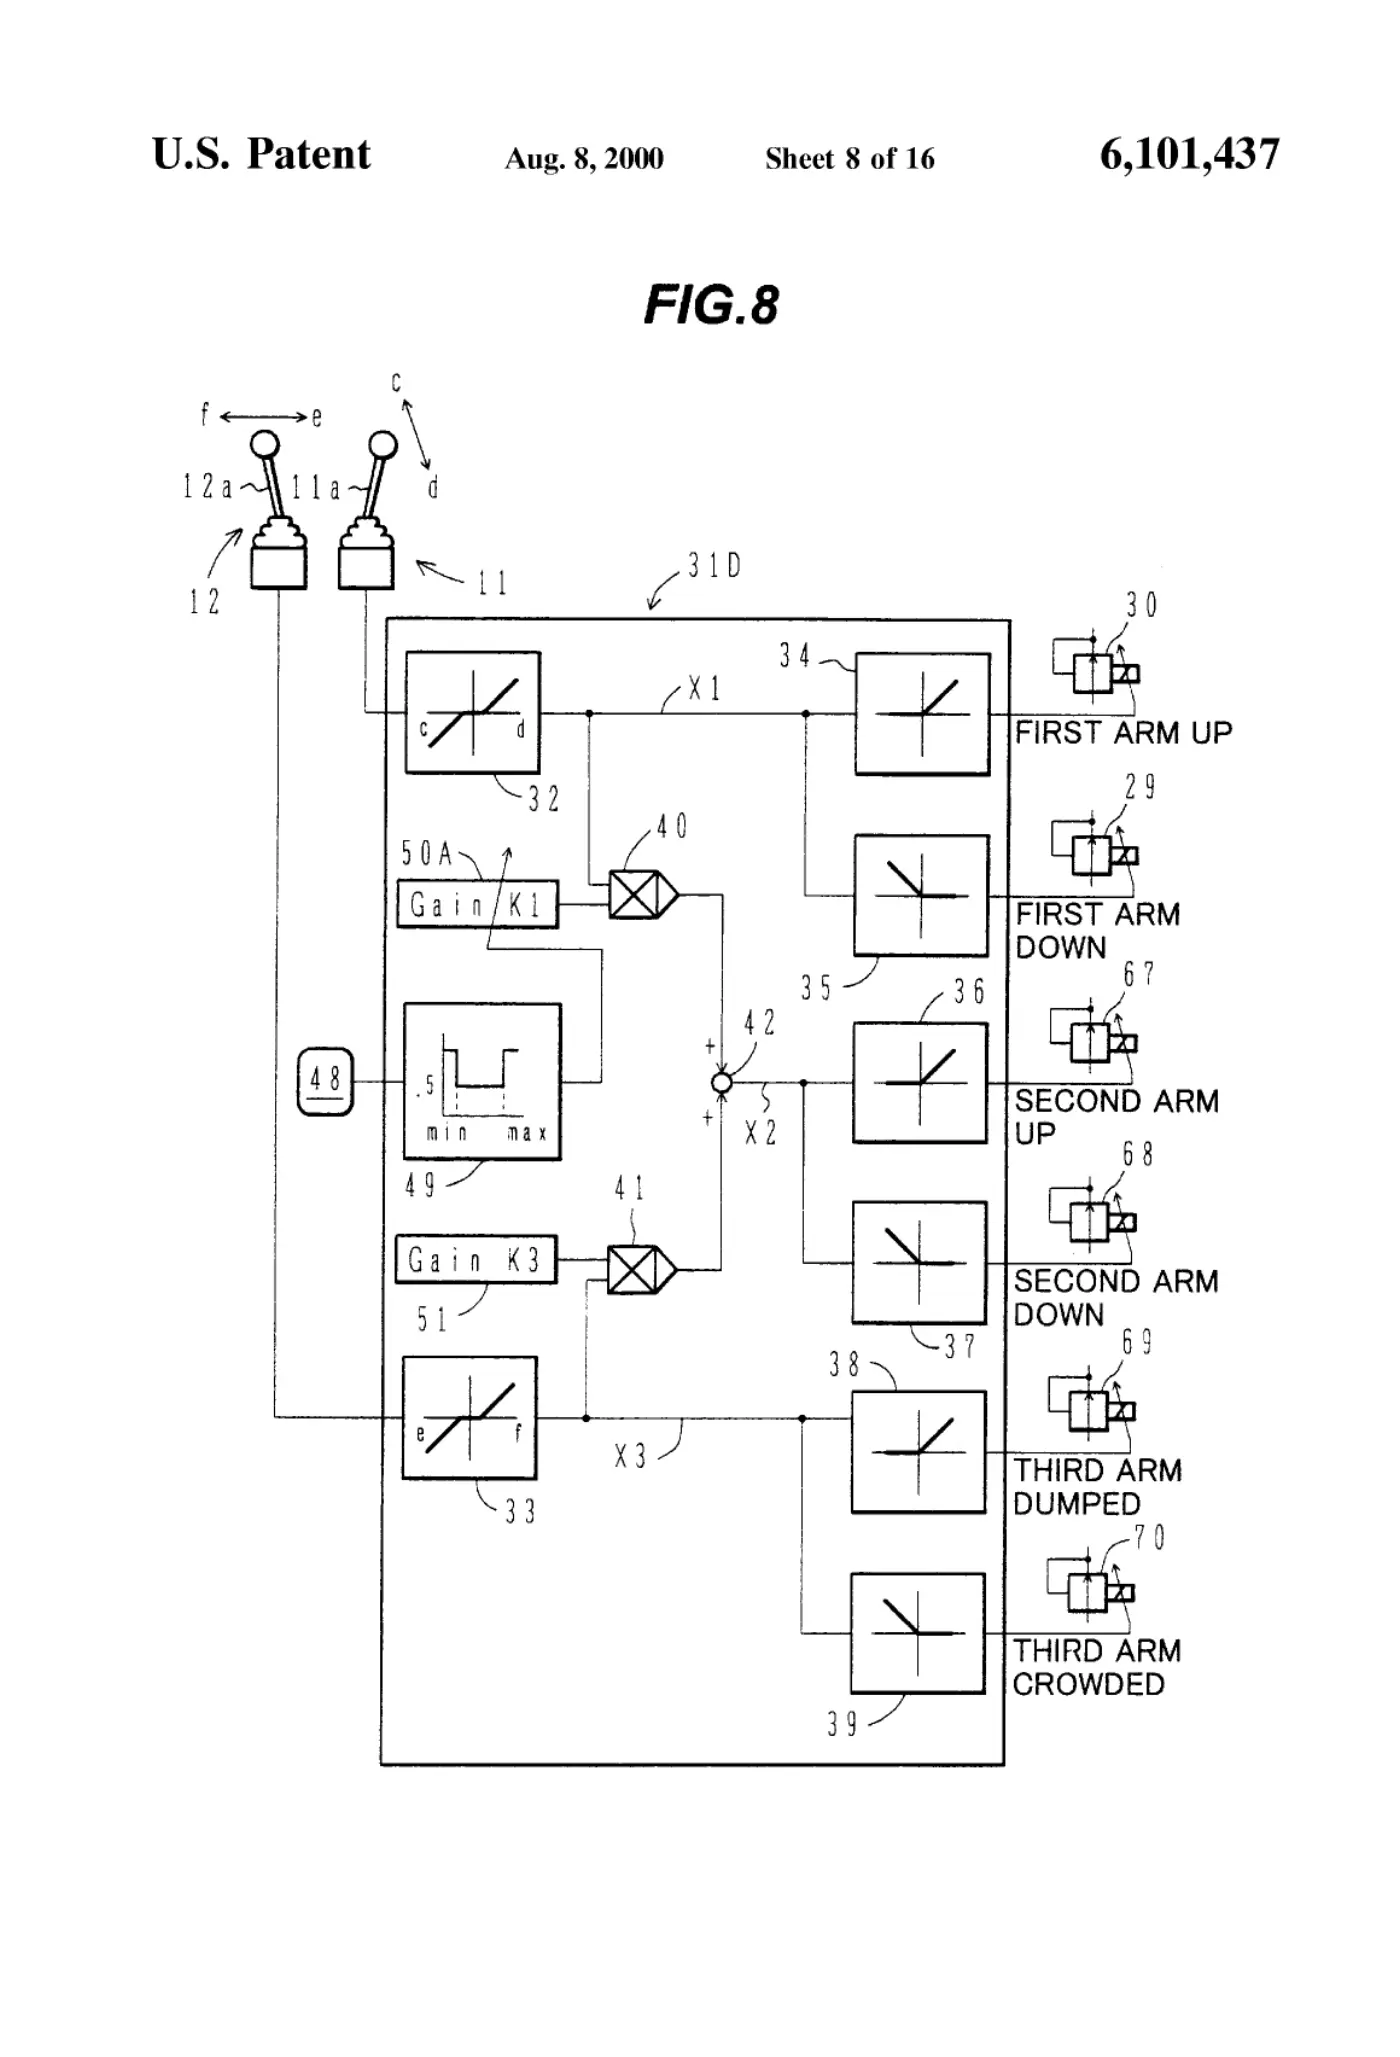
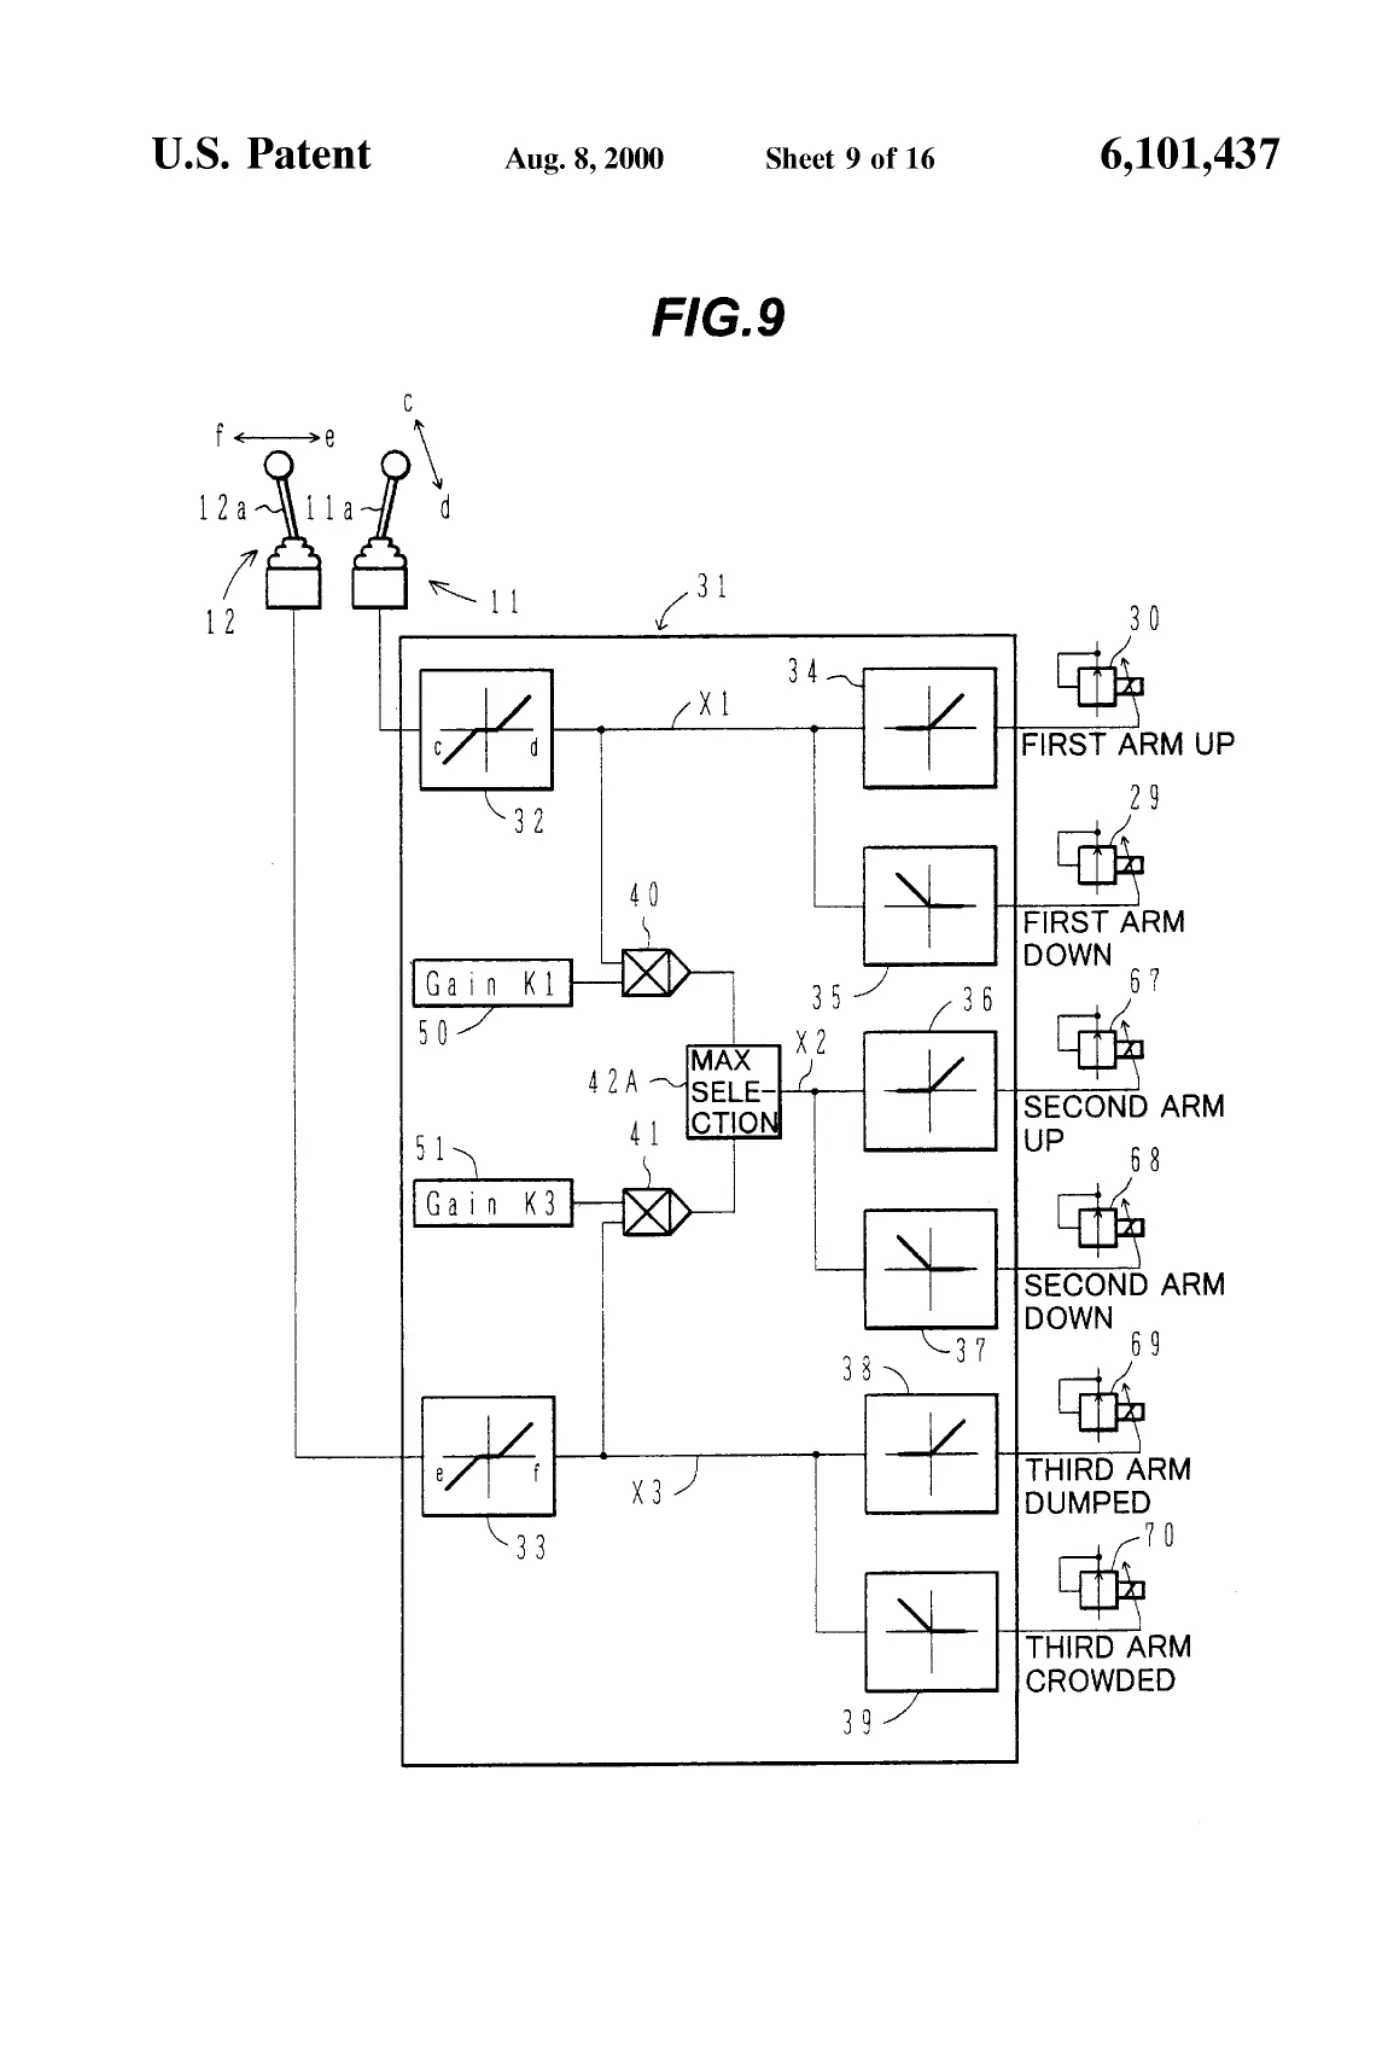
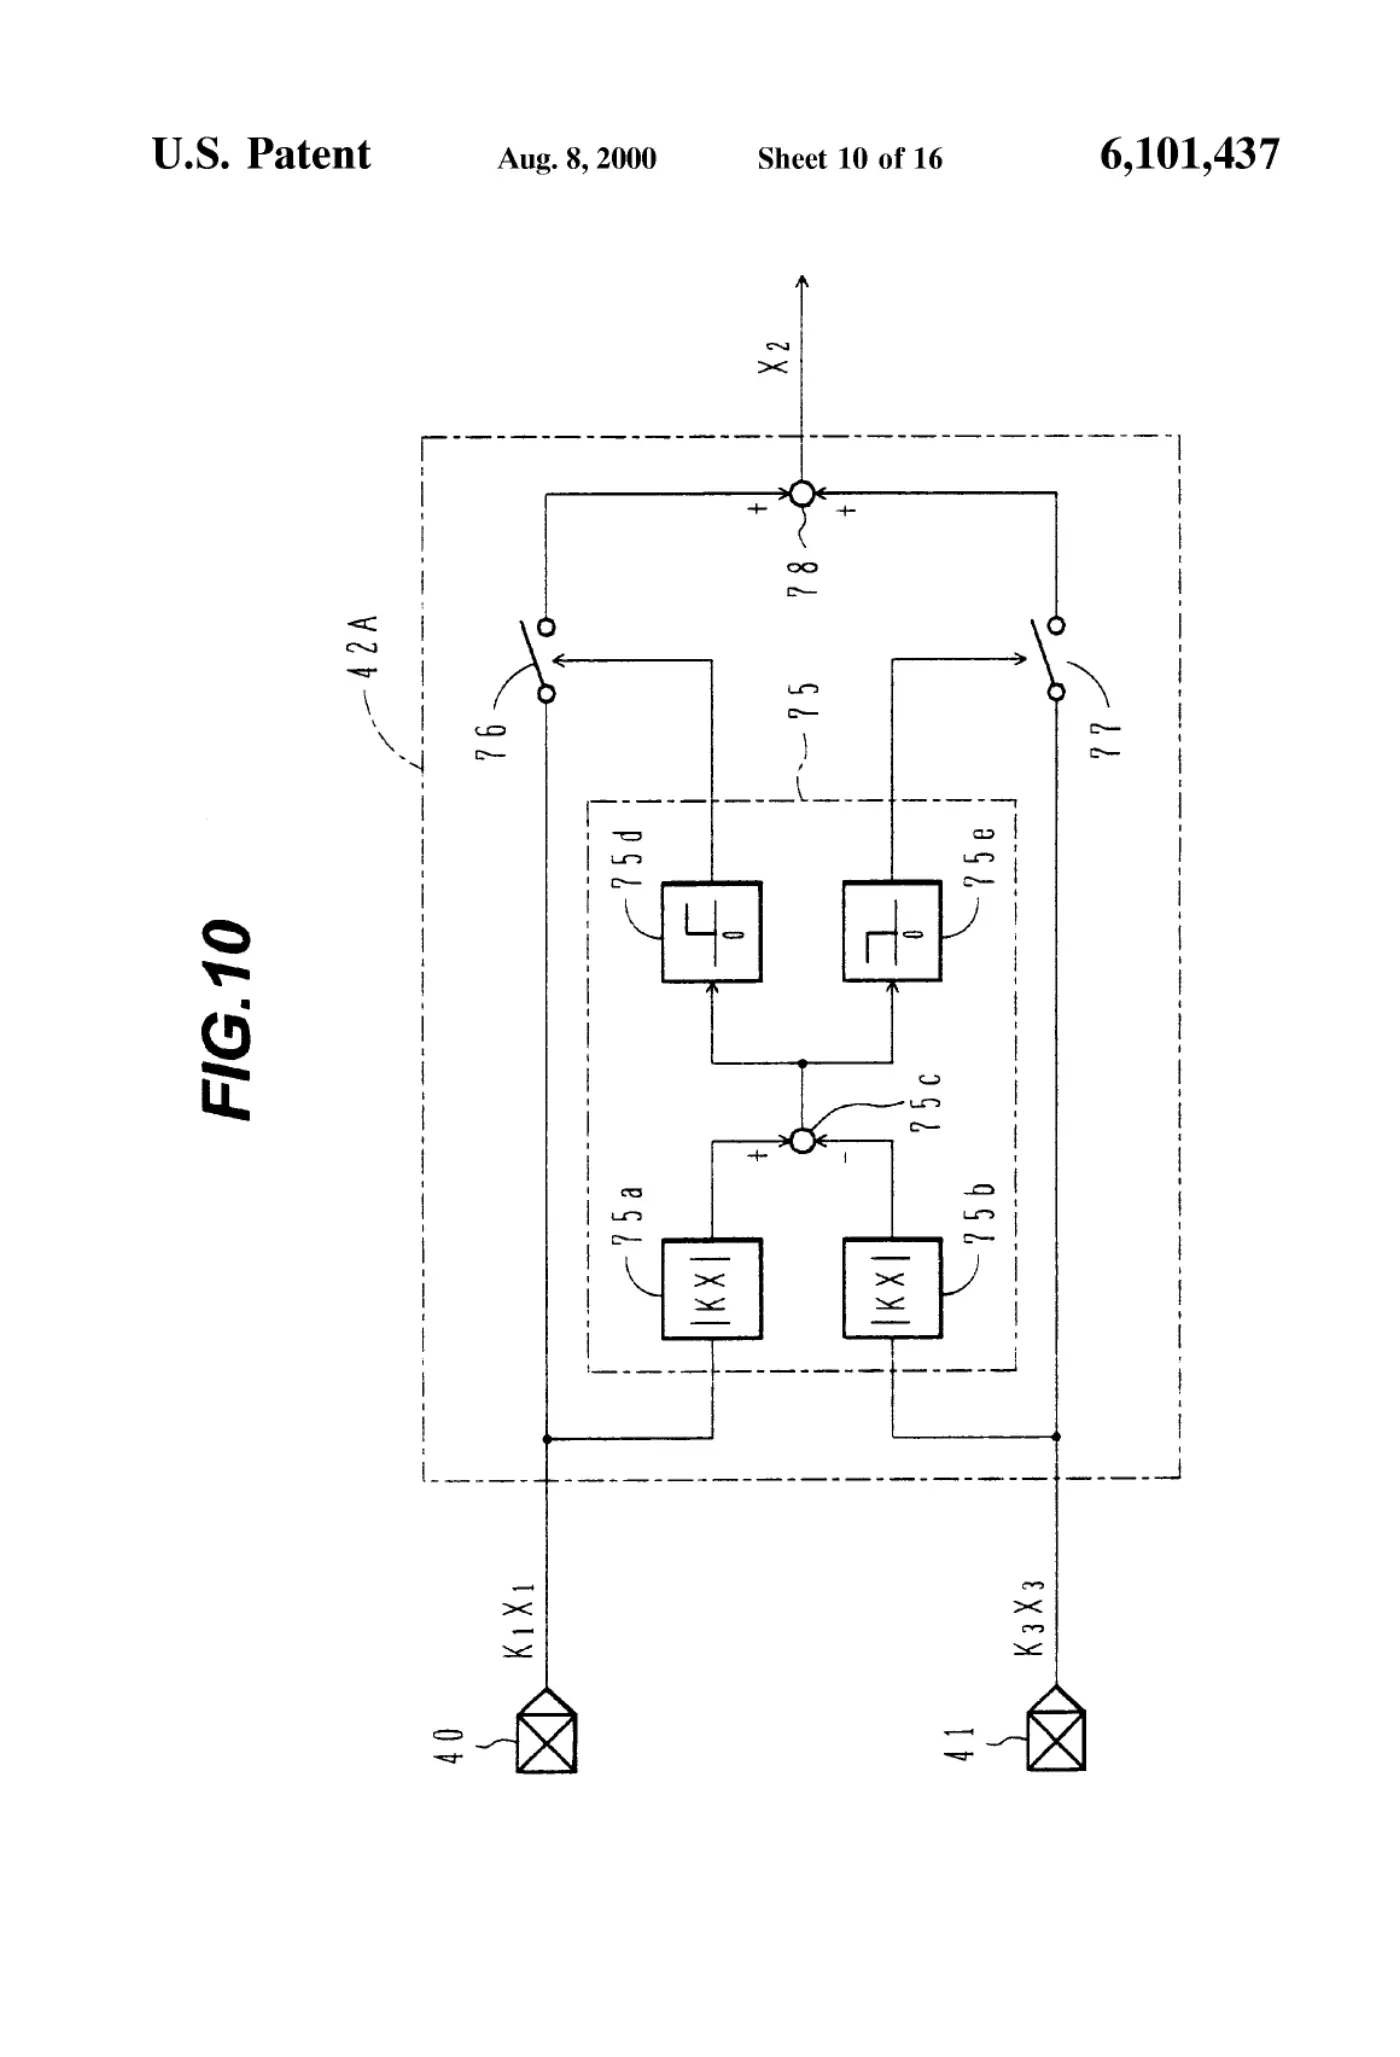
A speed command value X1 for a first arm 3 is decided depending on a lever input amount in the direction c, d. Assuming that the side d corresponding to move-up of the first arm is positive, the side c corresponding to move-down thereof is negative, and a speed command value resulted upon full lever operation and corresponding to a rated speed of the first arm is 1, X1 is given by -1<X1<1. A speed command value X3 for a third arm 5 is decided depending on a lever input amount in the direction e, f. Assuming that the side f corresponding to dumping of the third arm is positive, the side e corresponding to crowding thereof is negative, and a speed command value resulted upon full lever operation and corresponding to a rated speed of the third arm is 1, X3 is given by -1<X3<1. A speed command value X2 for a second arm 4 is here given by X2=K1×X1+K3×X3 on condition that the side corresponding to move-up of the second arm is positive. With such an operation control system for a 3-articulation type excavator, the excavator can be operated by operators having an ordinary skill continuously over a wide working area specific to 3-articulation type excavators with the same operating feeling as obtained with conventional 2-articulation type excavators.
Abstract
A speed command value X1 for a first arm 3 is decided depending on a lever input amount in the direction c, d. Assuming that the side d corresponding to move-up of the first arm is positive, the side c corresponding to move-down thereof is negative, and a speed command value resulted upon full lever operation and corresponding to a rated speed of the first arm is 1, X1 is given by -1<X1<1. A speed command value X3 for a third arm 5 is decided depending on a lever input amount in the direction e, f. Assuming that the side f corresponding to dumping of the third arm is positive, the side e corresponding to crowding thereof is negative, and a speed command value resulted upon full lever operation and corresponding to a rated speed of the third arm is 1, X3 is given by -1<X3<1. A speed command value X2 for a second arm 4 is here given by X2=K1×X1+K3×X3 on condition that the side corresponding to move-up of the second arm is positive. With such an operation control system for a 3-articulation type excavator, the excavator can be operated by operators having an ordinary skill continuously over a wide working area specific to 3-articulation type excavators with the same operating feeling as obtained with conventional 2-articulation type excavators.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
[0005]Sheet 5.
[0006]Sheet 6.
[0007]Sheet 7.
[0008]Sheet 8.
[0009]Sheet 9.
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003141, “Operation control device for three-joint excavator,” published September 15, 2026 at 19:37:39 UTC, https://opentechnical.org/p/OT-2026-000003141.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.