OT-2026-000003149
Reconfigurable modular joint and robots produced therefrom
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003149
- Classification
- Robotics & Automation › Robot Architectures
- Assignee
- ENGINEERING SERVICES INC
- Original source
- US-6084373-A, the United States Patent and Trademark Office, 4 July 2000
- Document SHA-256
- 7aa71fbda503be8e08ab36c38ab7370cd2b70d172be0d0196829a2cfd9421bae
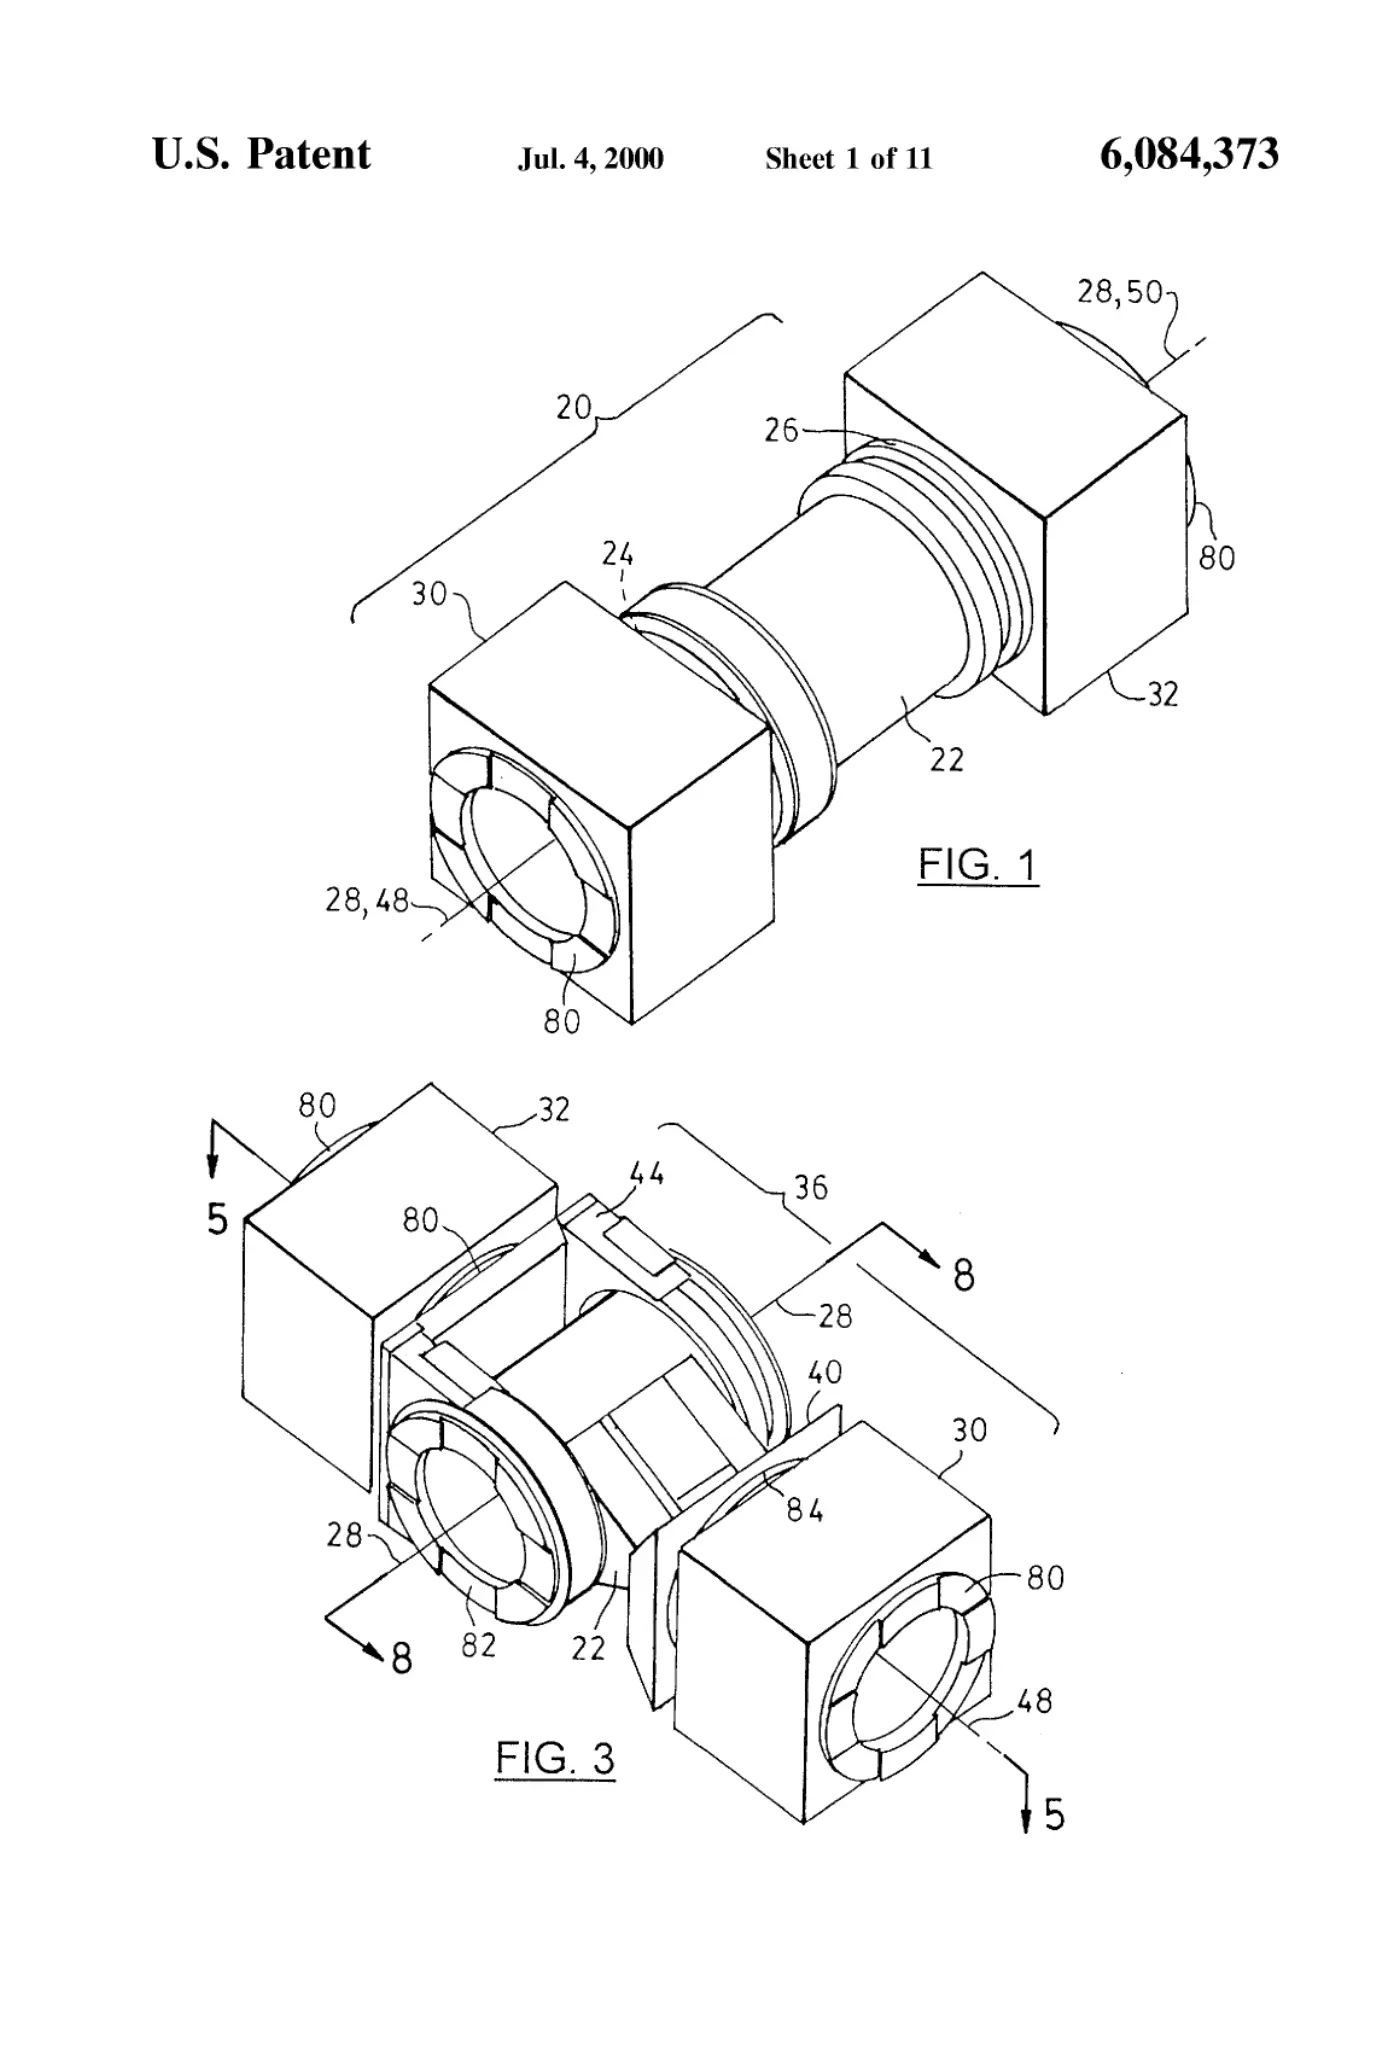
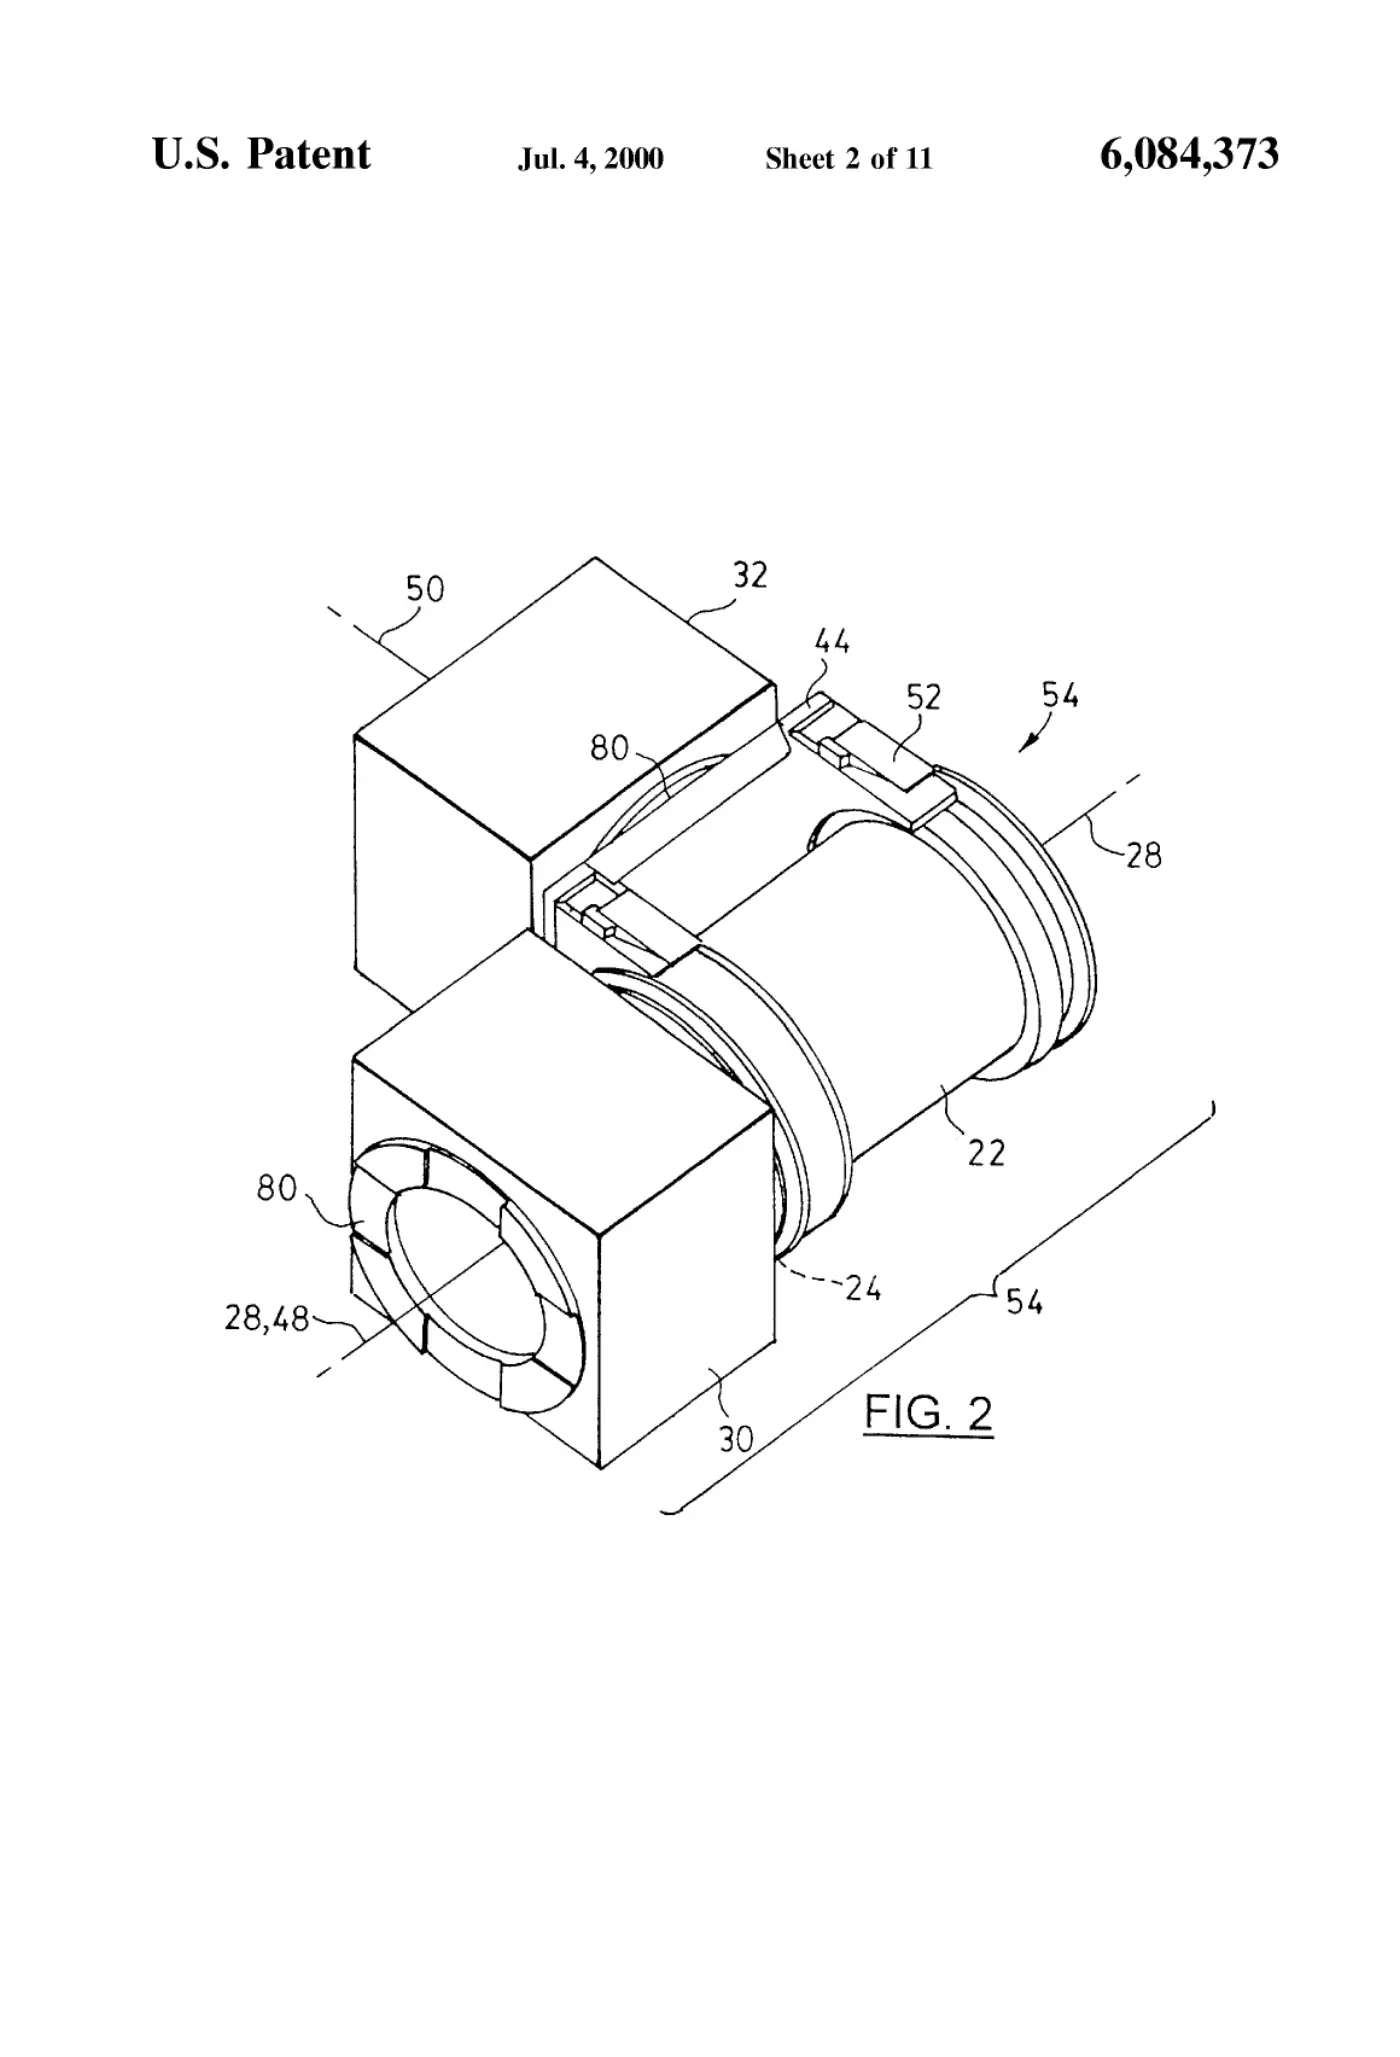
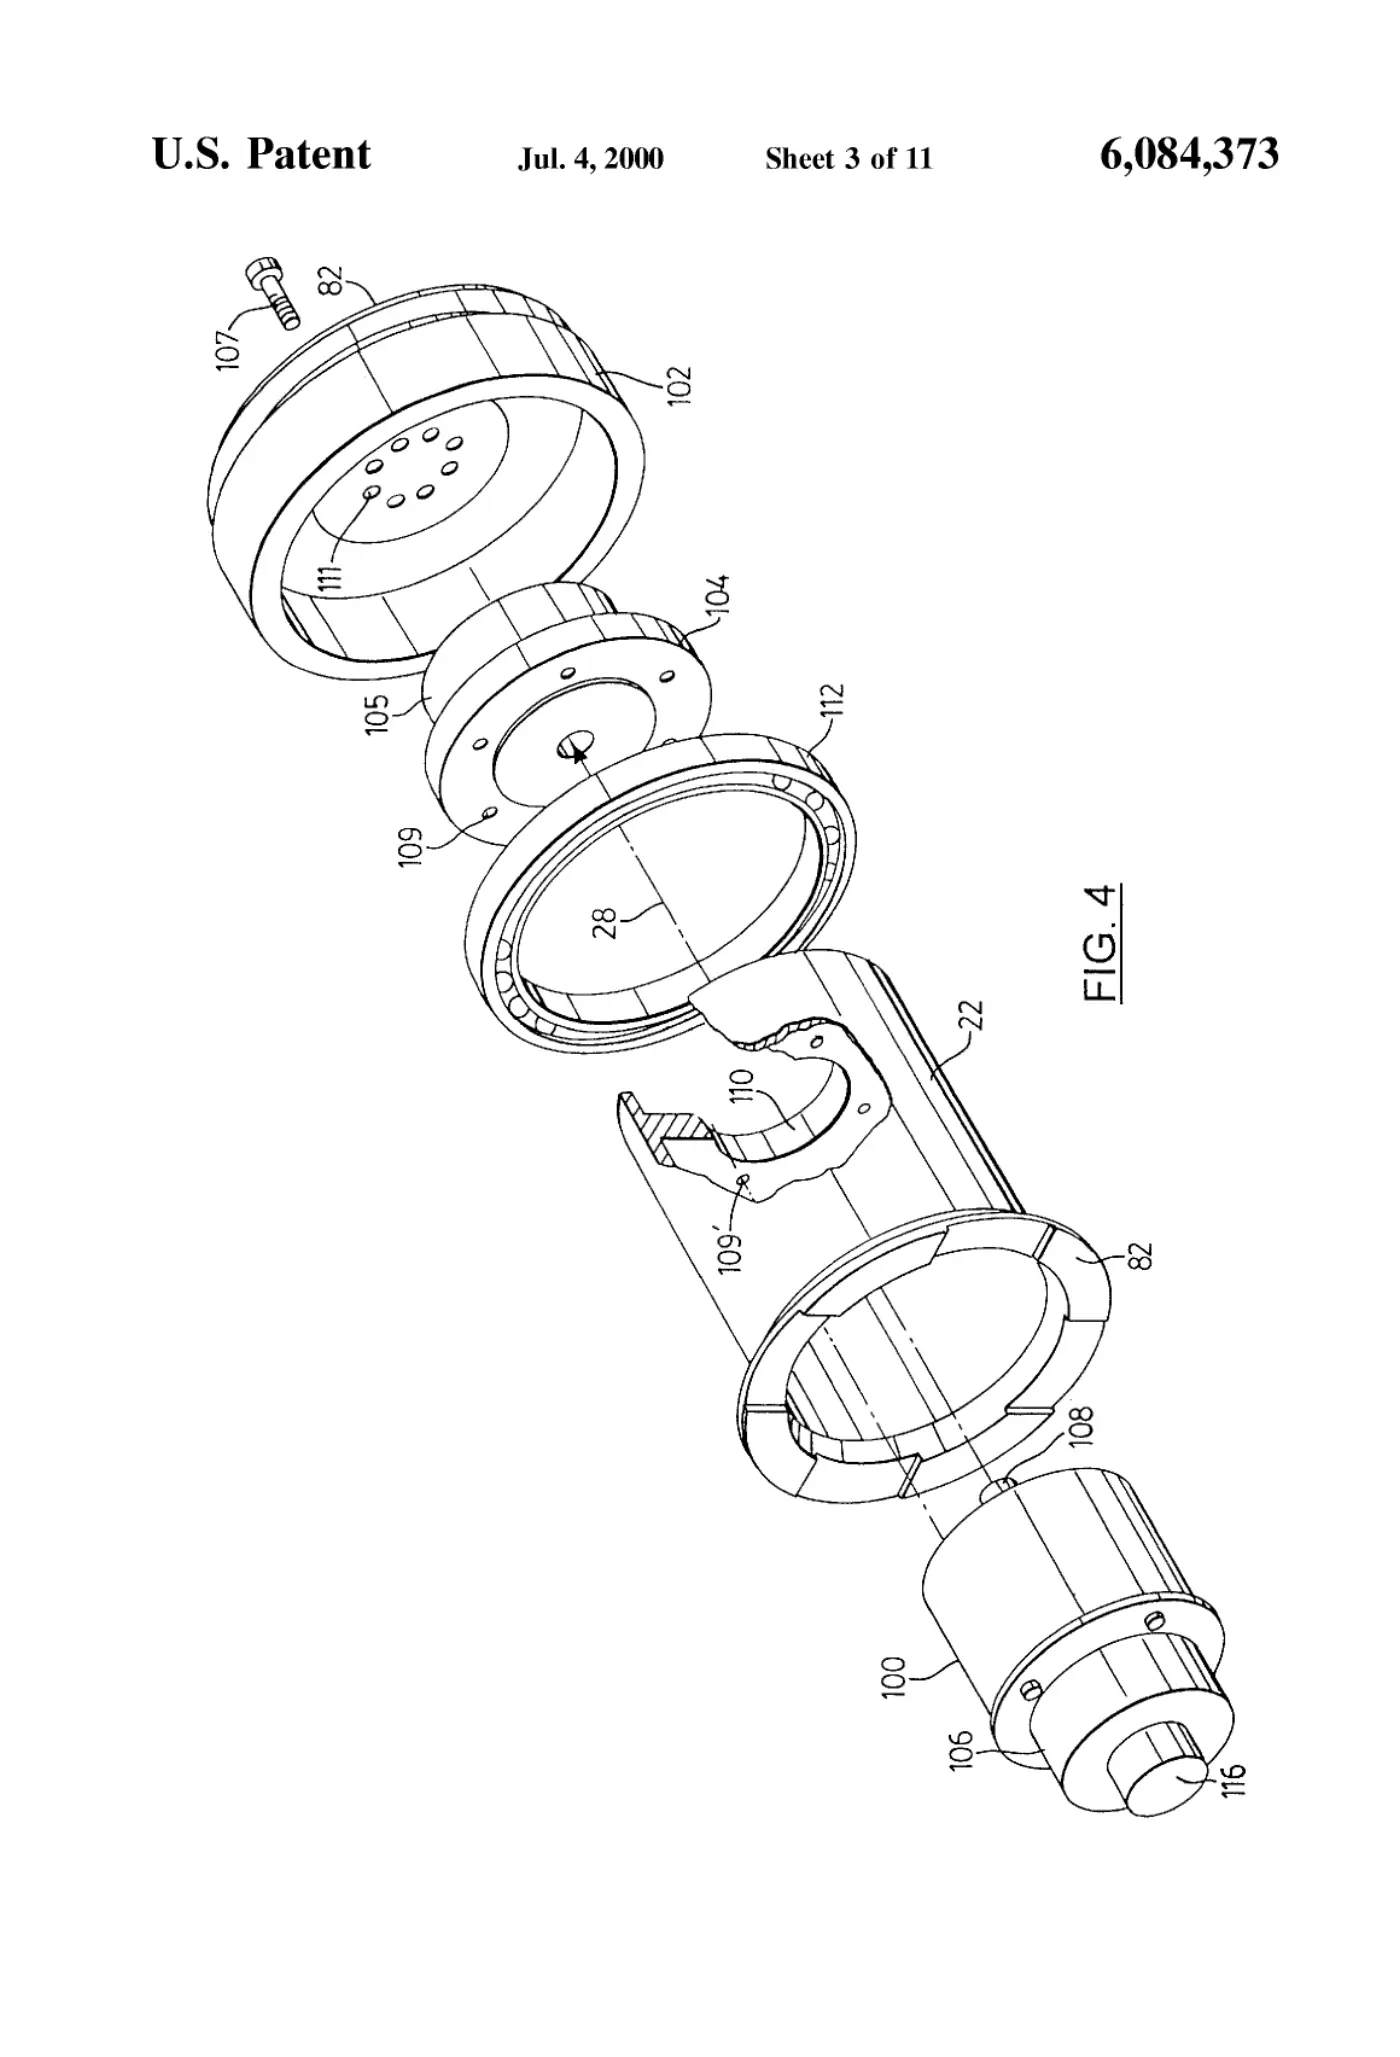
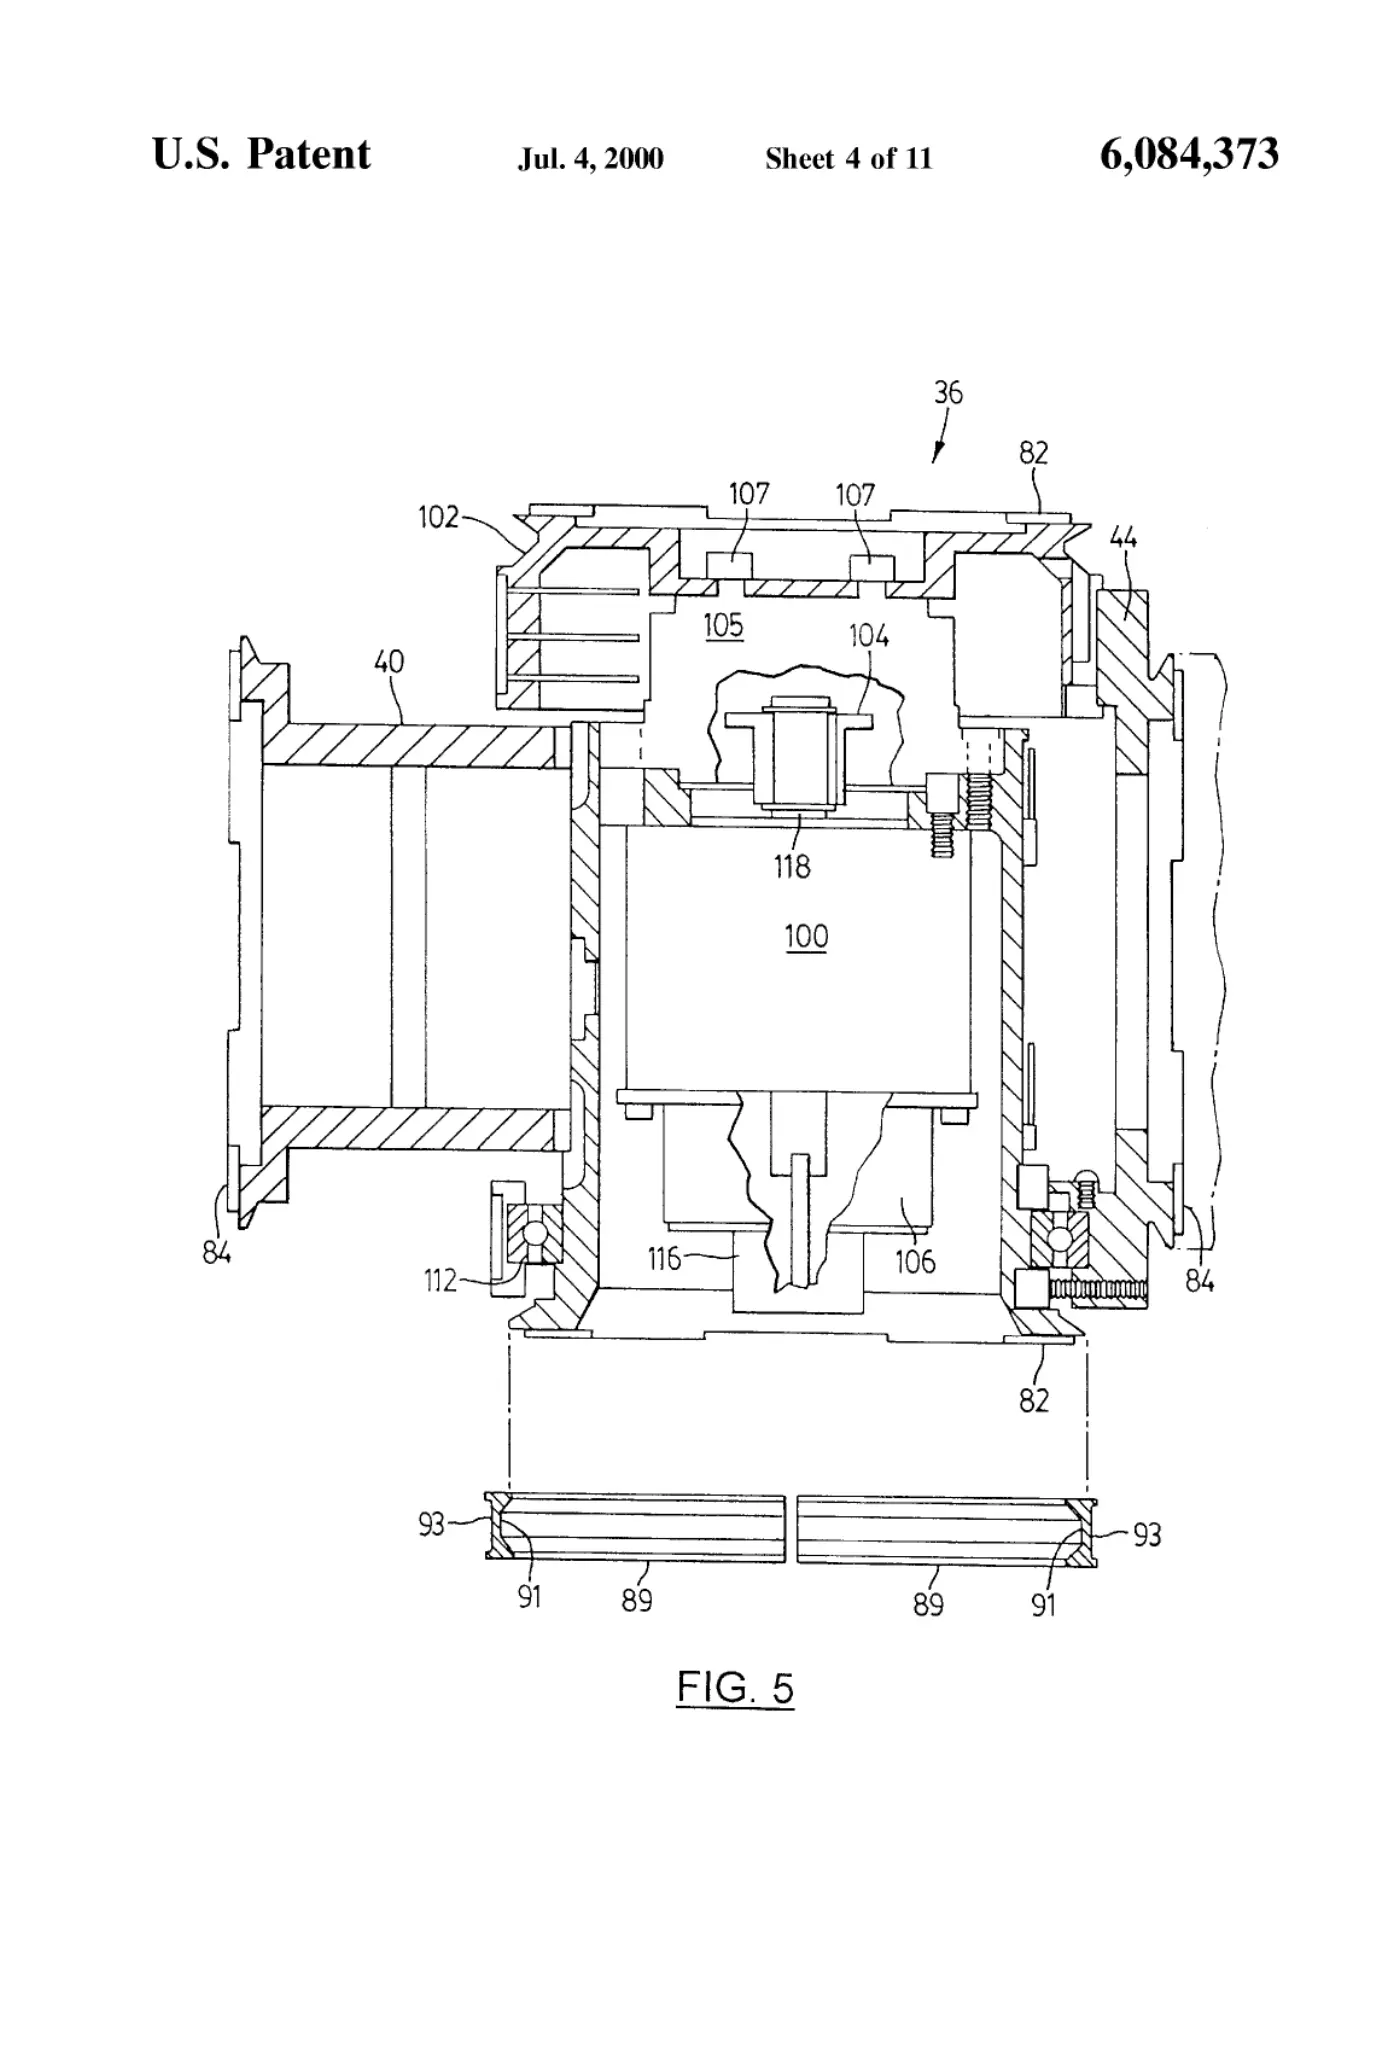
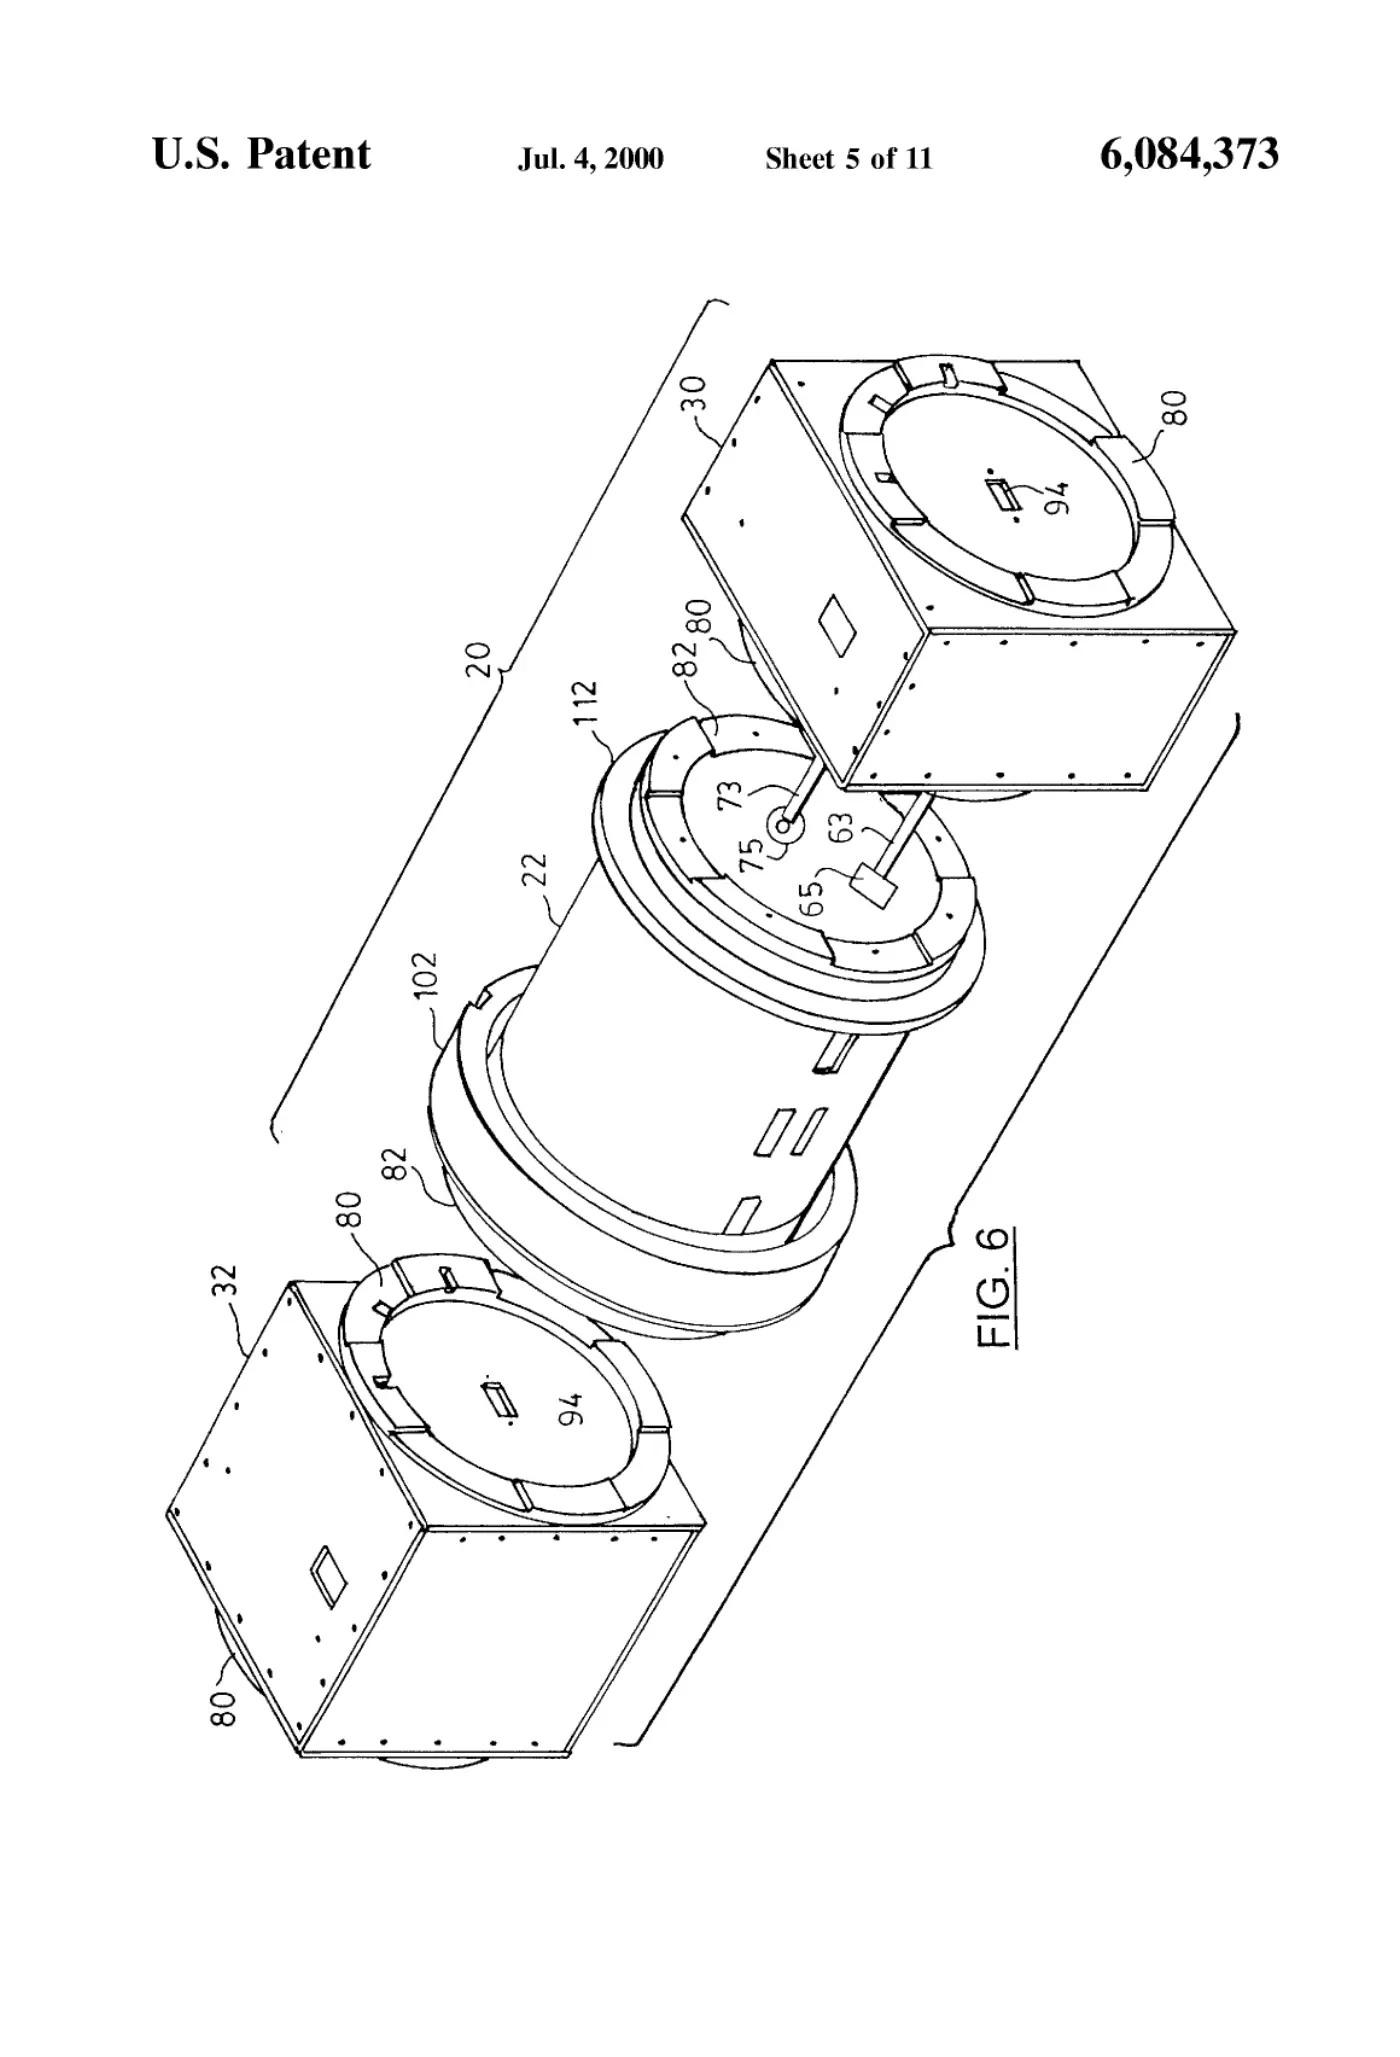
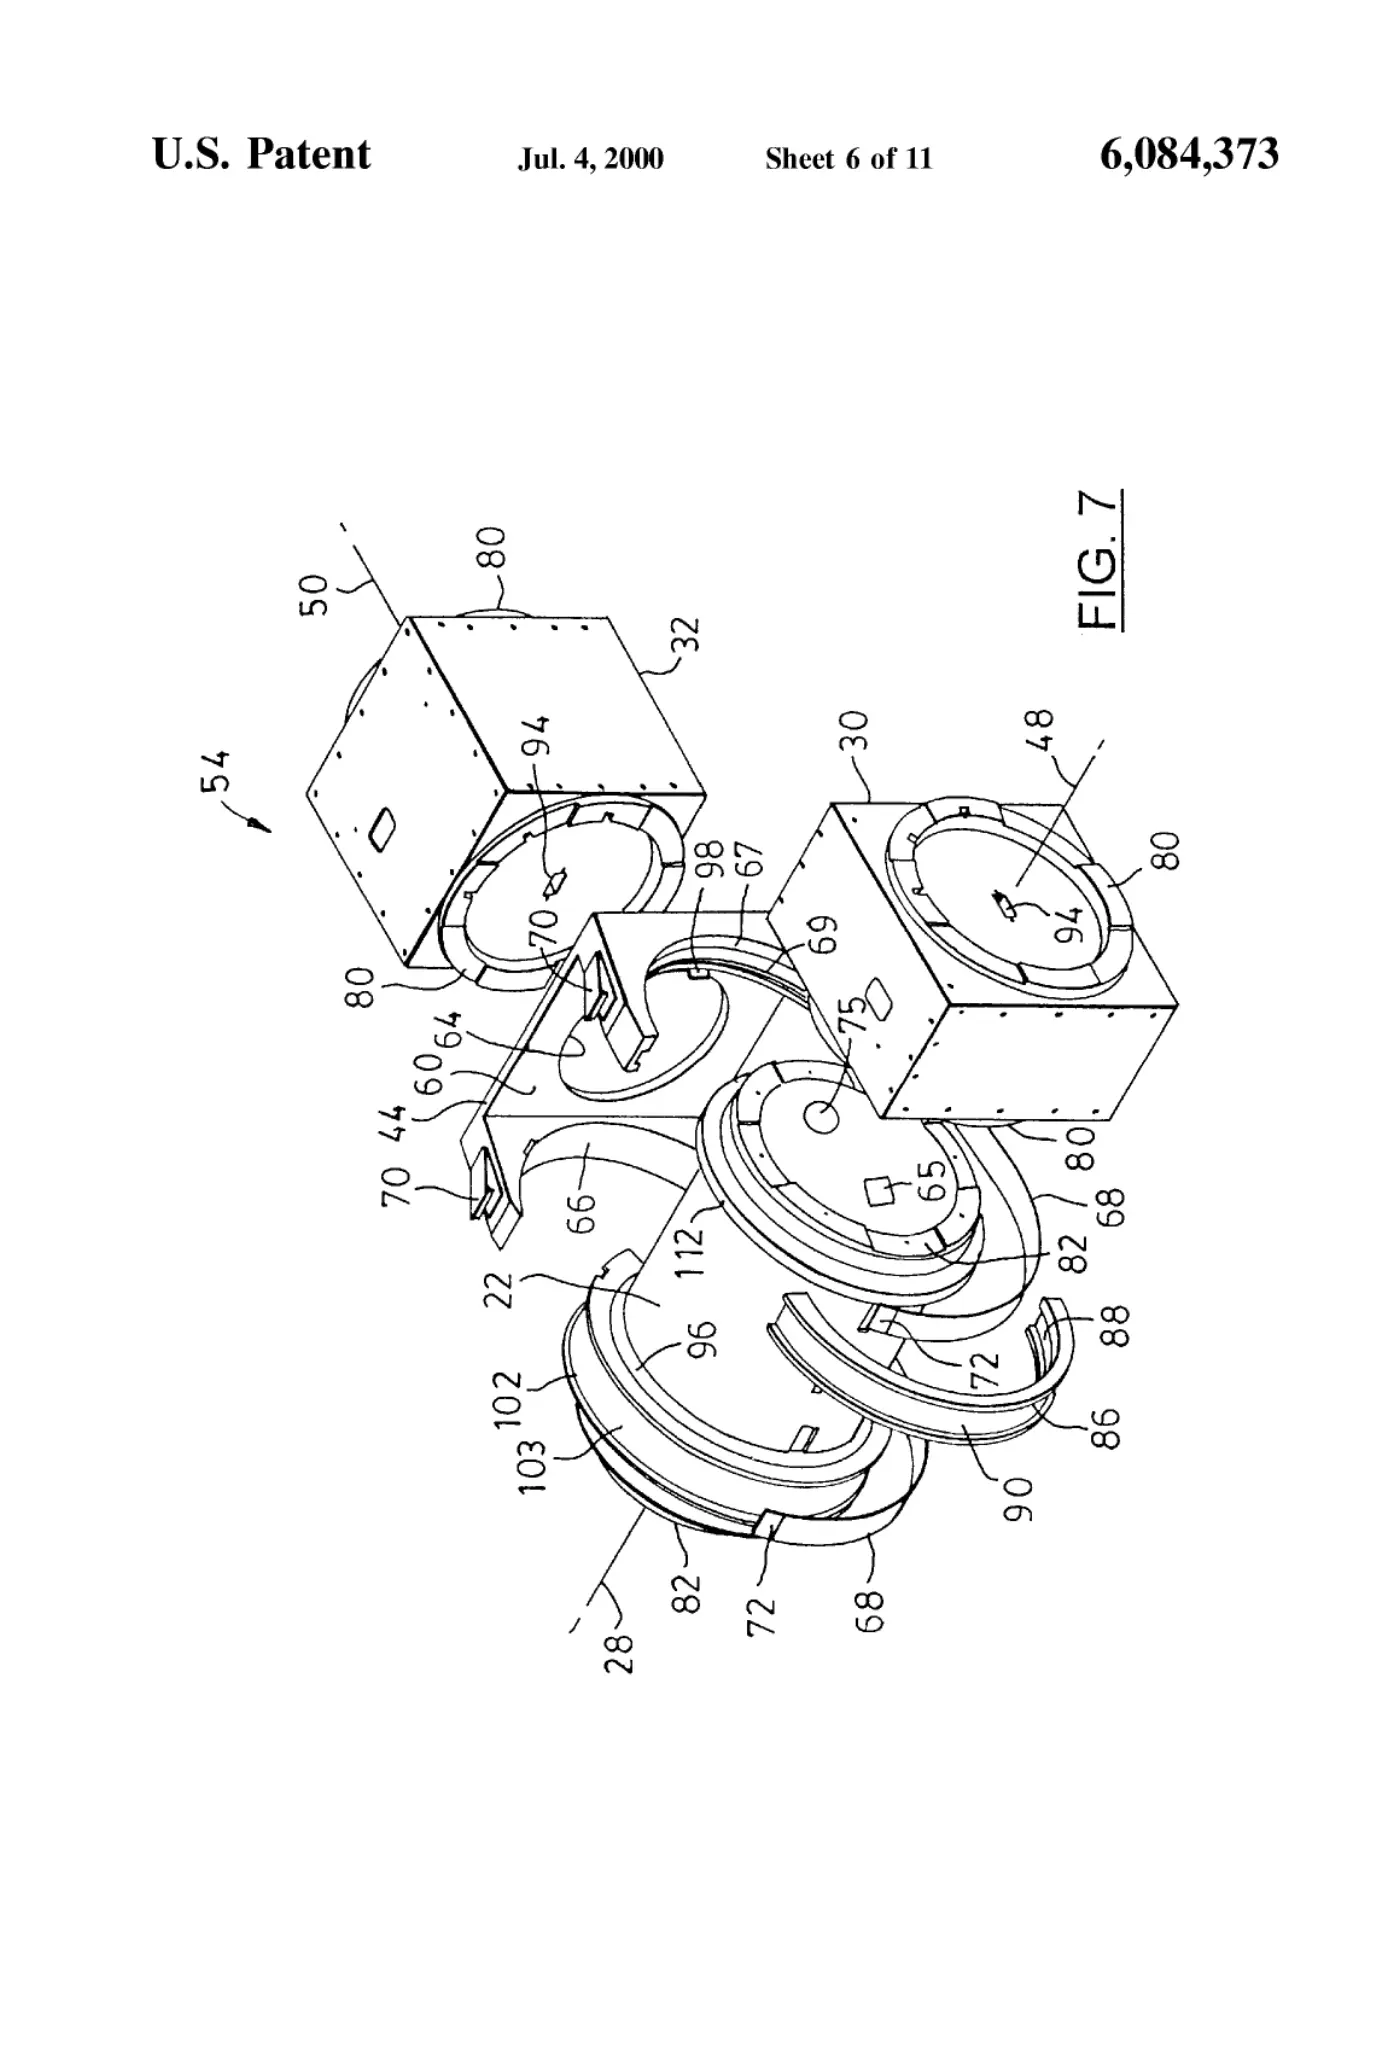
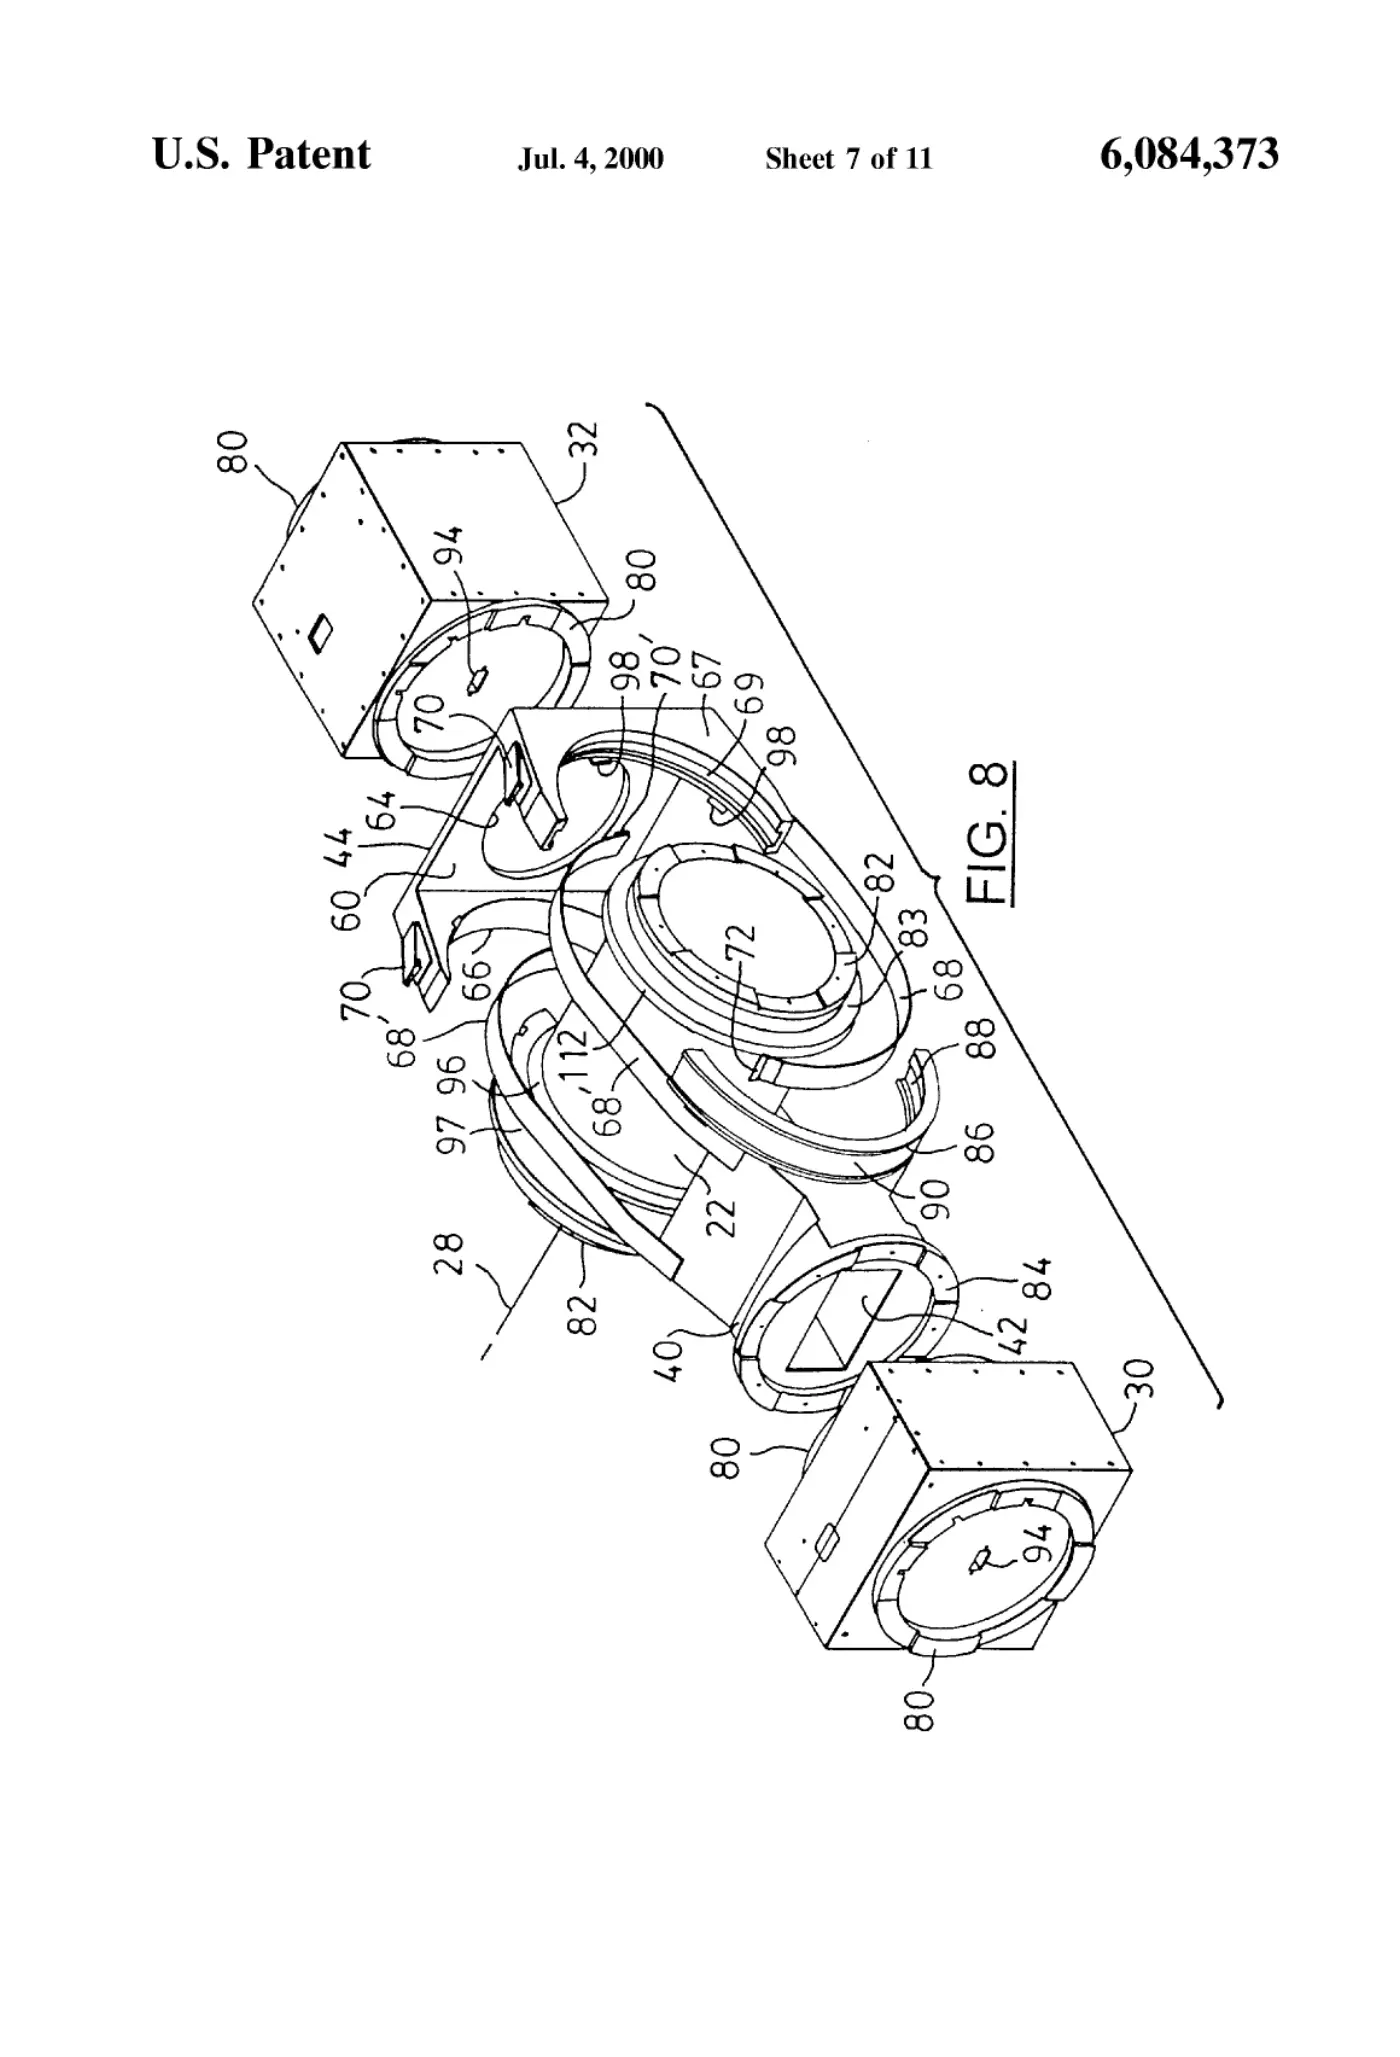
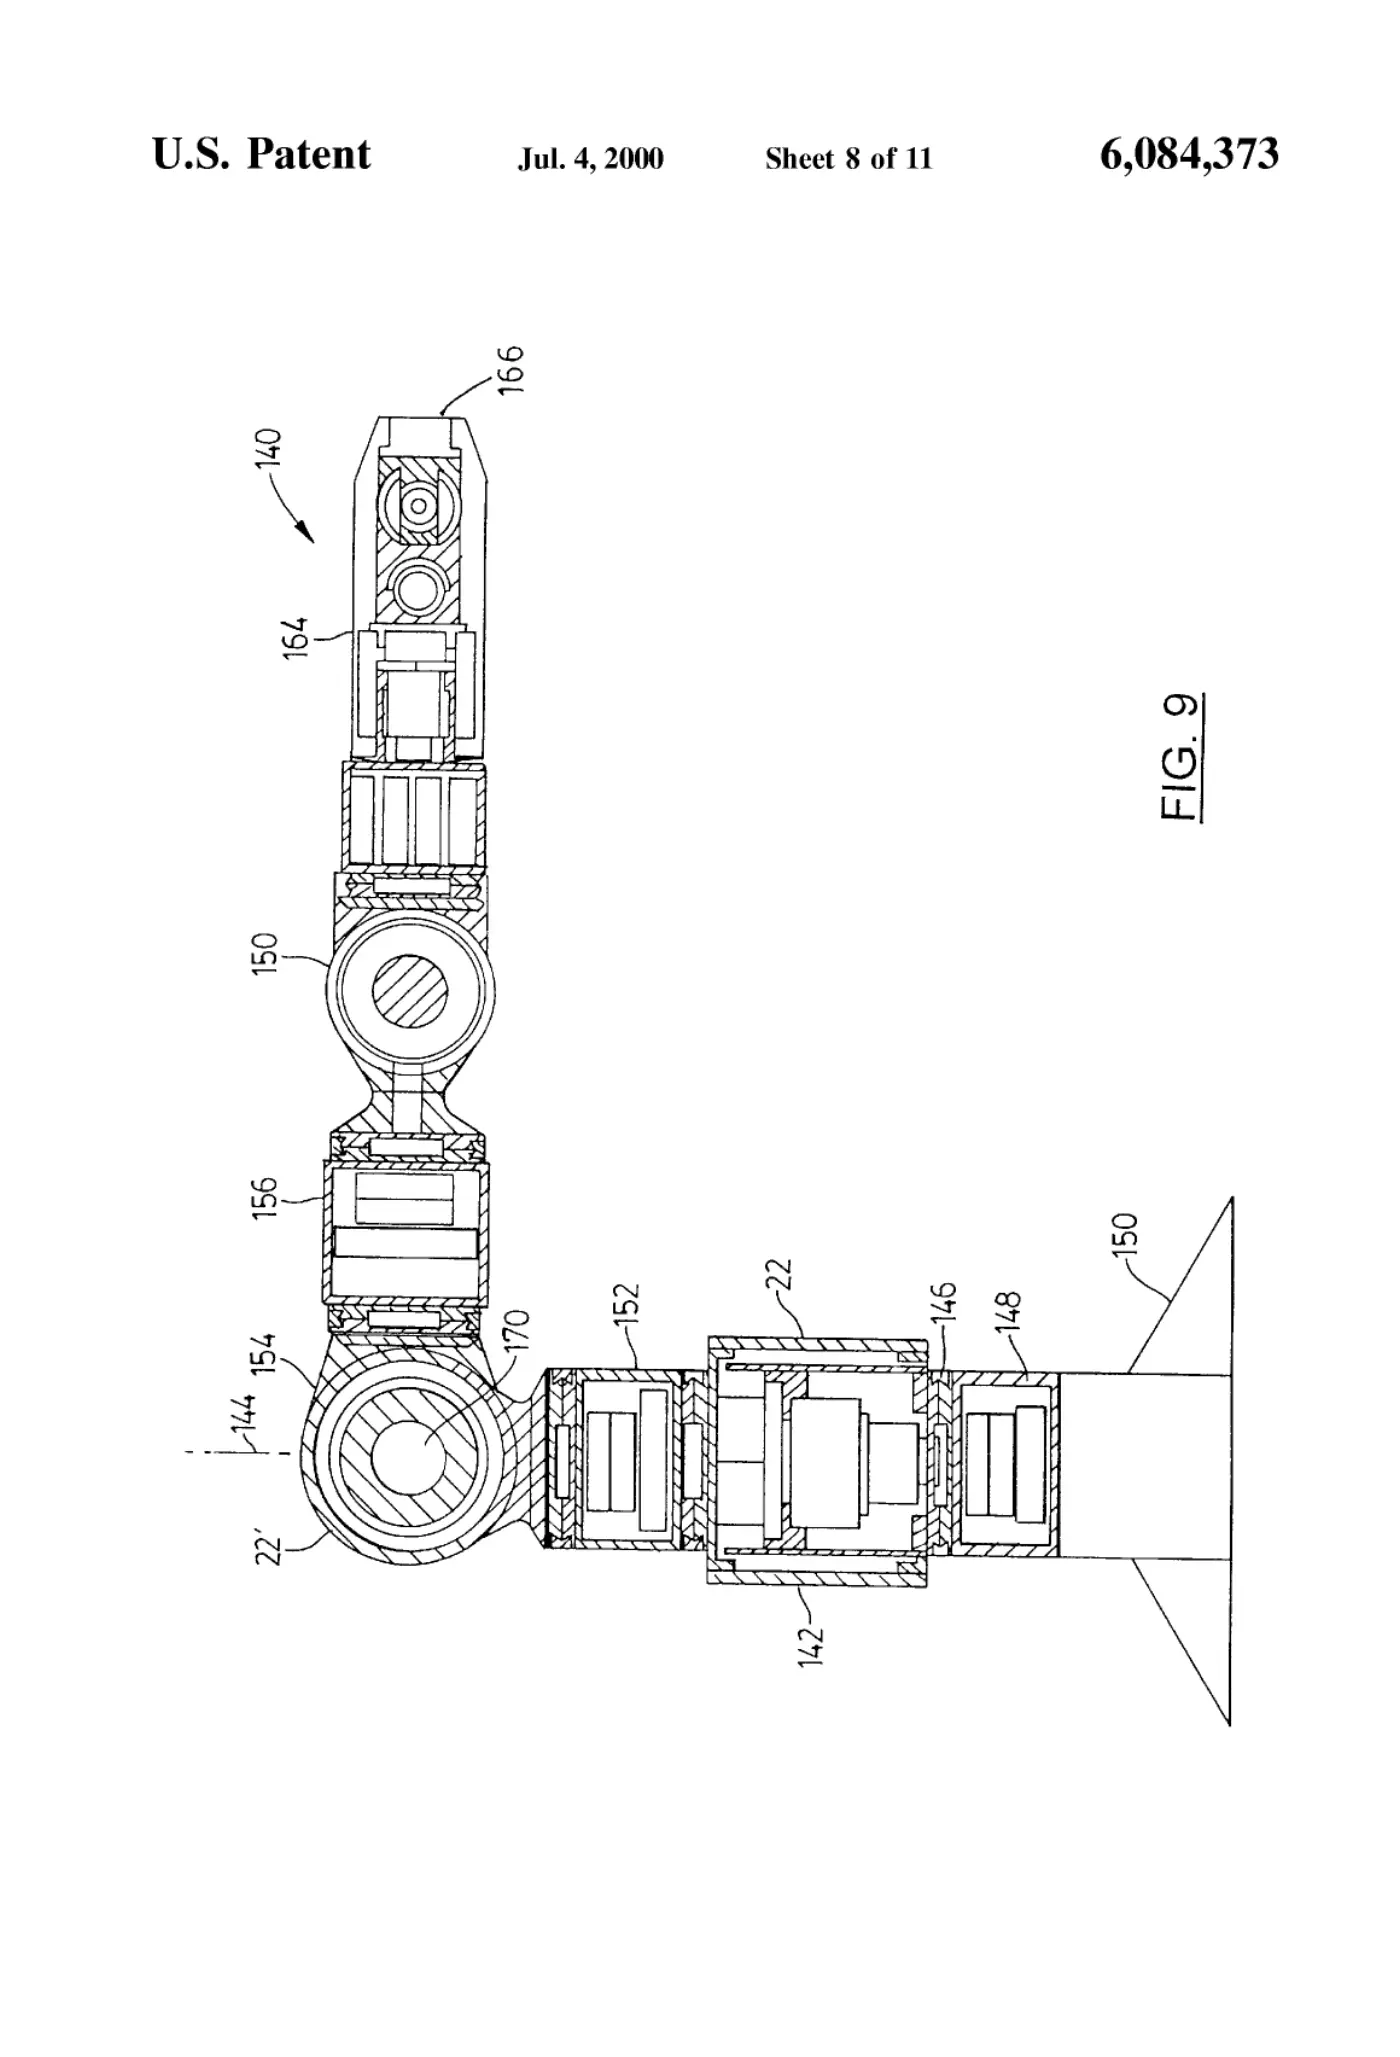
The present invention provides a reconfigurable modular drive joint that can be used as the basis for building and configuring robotic and automated systems as an interconnected network of individual nodes, with each node representing a single modular joint. Each modular joint can be quickly set up in either a roll, pitch or yaw configuration. A large number of different robot structures can be built using a small number of the modular joints in any of these three configurations. The modules are equipped with quick-connect mechanisms so that a new robot structure can be assembled in a few minutes. A robot or other automated system assembled from such modular joints is a true reconfigurable and modular system. The control system is decentralized. Each modular joint is provided with its own built-in control system and electronics. The modular joints each include a motor and associated sensors. An embedded control system including a power amplifier for the motor, a sensor interface, microprocessor, and communication circuitry are provided. The only external connections to each module is a communication bus between the modules and the host computer and a power supply bus.
Abstract
The present invention provides a reconfigurable modular drive joint that can be used as the basis for building and configuring robotic and automated systems as an interconnected network of individual nodes, with each node representing a single modular joint. Each modular joint can be quickly set up in either a roll, pitch or yaw configuration. A large number of different robot structures can be built using a small number of the modular joints in any of these three configurations. The modules are equipped with quick-connect mechanisms so that a new robot structure can be assembled in a few minutes. A robot or other automated system assembled from such modular joints is a true reconfigurable and modular system. The control system is decentralized. Each modular joint is provided with its own built-in control system and electronics. The modular joints each include a motor and associated sensors. An embedded control system including a power amplifier for the motor, a sensor interface, microprocessor, and communication circuitry are provided. The only external connections to each module is a communication bus between the modules and the host computer and a power supply bus.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
[0005]Sheet 5.
[0006]Sheet 6.
[0007]Sheet 7.
[0008]Sheet 8.
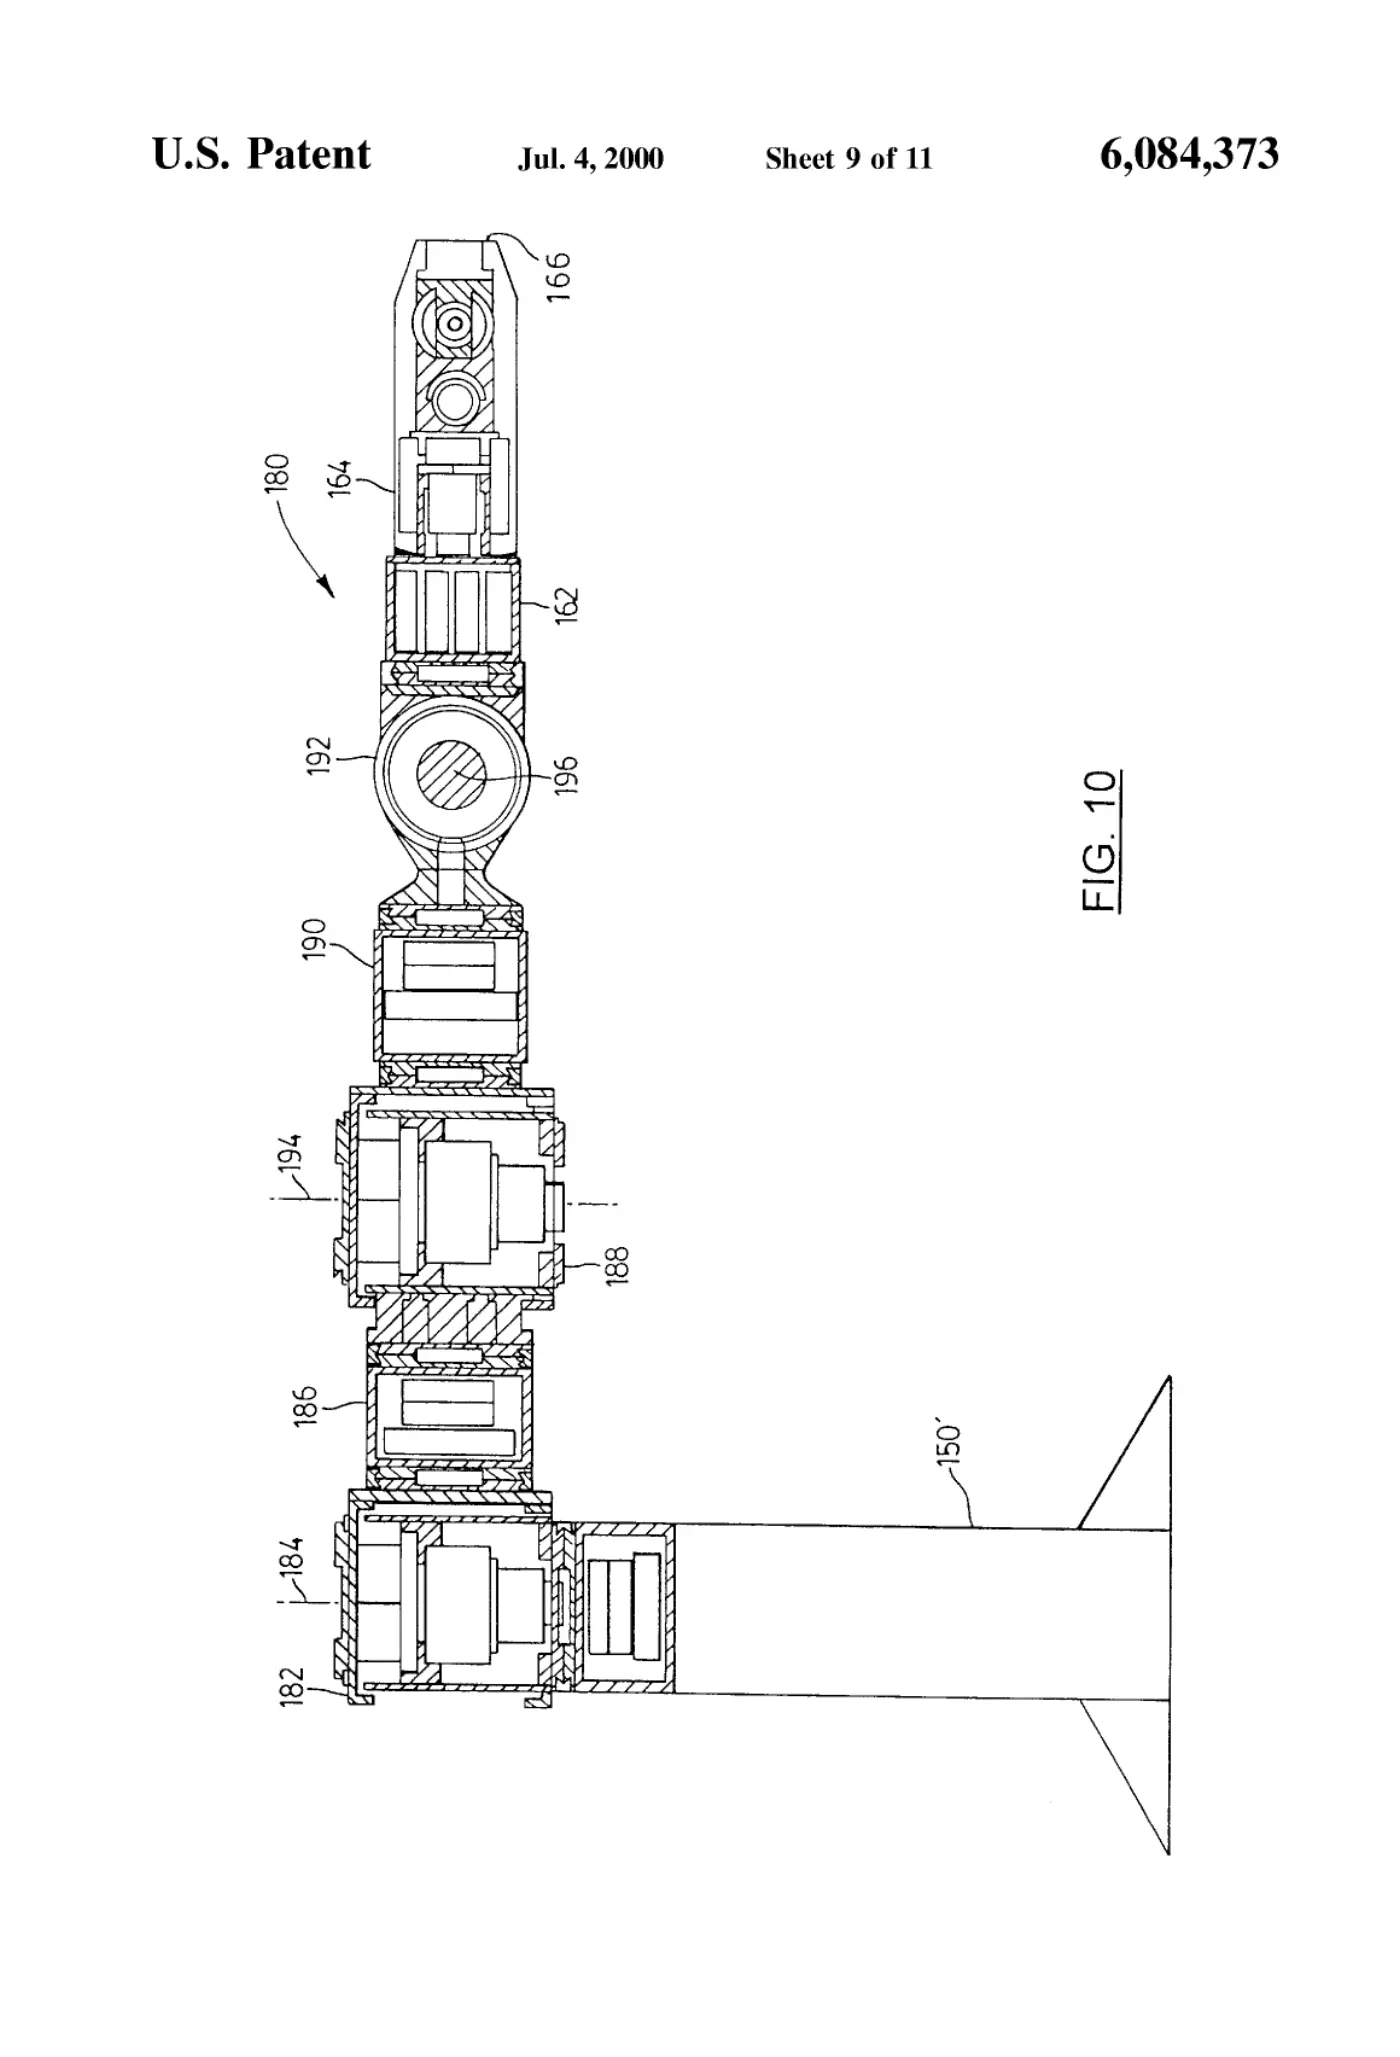
[0009]Sheet 9.
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003149, “Reconfigurable modular joint and robots produced therefrom,” published September 15, 2026 at 19:39:11 UTC, https://opentechnical.org/p/OT-2026-000003149.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.