OT-2026-000003193
Method and apparatus for controlling an implement of a work machine using linkage angles
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003193
- Classification
- Industrial Motion & Power Transmission › Fluid Power
- Assignee
- CATERPILLAR INC
- Original source
- US-5875701-A, the United States Patent and Trademark Office, 2 March 1999
- Document SHA-256
- 00398757d999dd85060ecf4961c0510c1ecaa53db7bdab3dd342f646f0259c55
An apparatus for controllably moving a work implement is disclosed. The implement is connected to a work machine and is moveable in response to operation of a hydraulic cylinder. The apparatus includes an operator controlled joystick. A joystick position sensor senses the position of the joystick and responsively generates an operator command signal. Boom and bucket angle sensors sense the position of the work implement and responsively produces an boom angle signal and a bucket angle signal respectively. A microprocessor based controller receives the boom angle, bucket angle, and operator command signals, modifies the operator command signal, and produces an electrical valve signal in response to the modified operator command signal. An electrohydraulic valve receives the electrical valve signal, and controllably provides hydraulic fluid flow to the hydraulic cylinder in response to a magnitude of the electrical valve signal.
Abstract
An apparatus for controllably moving a work implement is disclosed. The implement is connected to a work machine and is moveable in response to operation of a hydraulic cylinder. The apparatus includes an operator controlled joystick. A joystick position sensor senses the position of the joystick and responsively generates an operator command signal. Boom and bucket angle sensors sense the position of the work implement and responsively produces an boom angle signal and a bucket angle signal respectively. A microprocessor based controller receives the boom angle, bucket angle, and operator command signals, modifies the operator command signal, and produces an electrical valve signal in response to the modified operator command signal. An electrohydraulic valve receives the electrical valve signal, and controllably provides hydraulic fluid flow to the hydraulic cylinder in response to a magnitude of the electrical valve signal.
1. Drawings
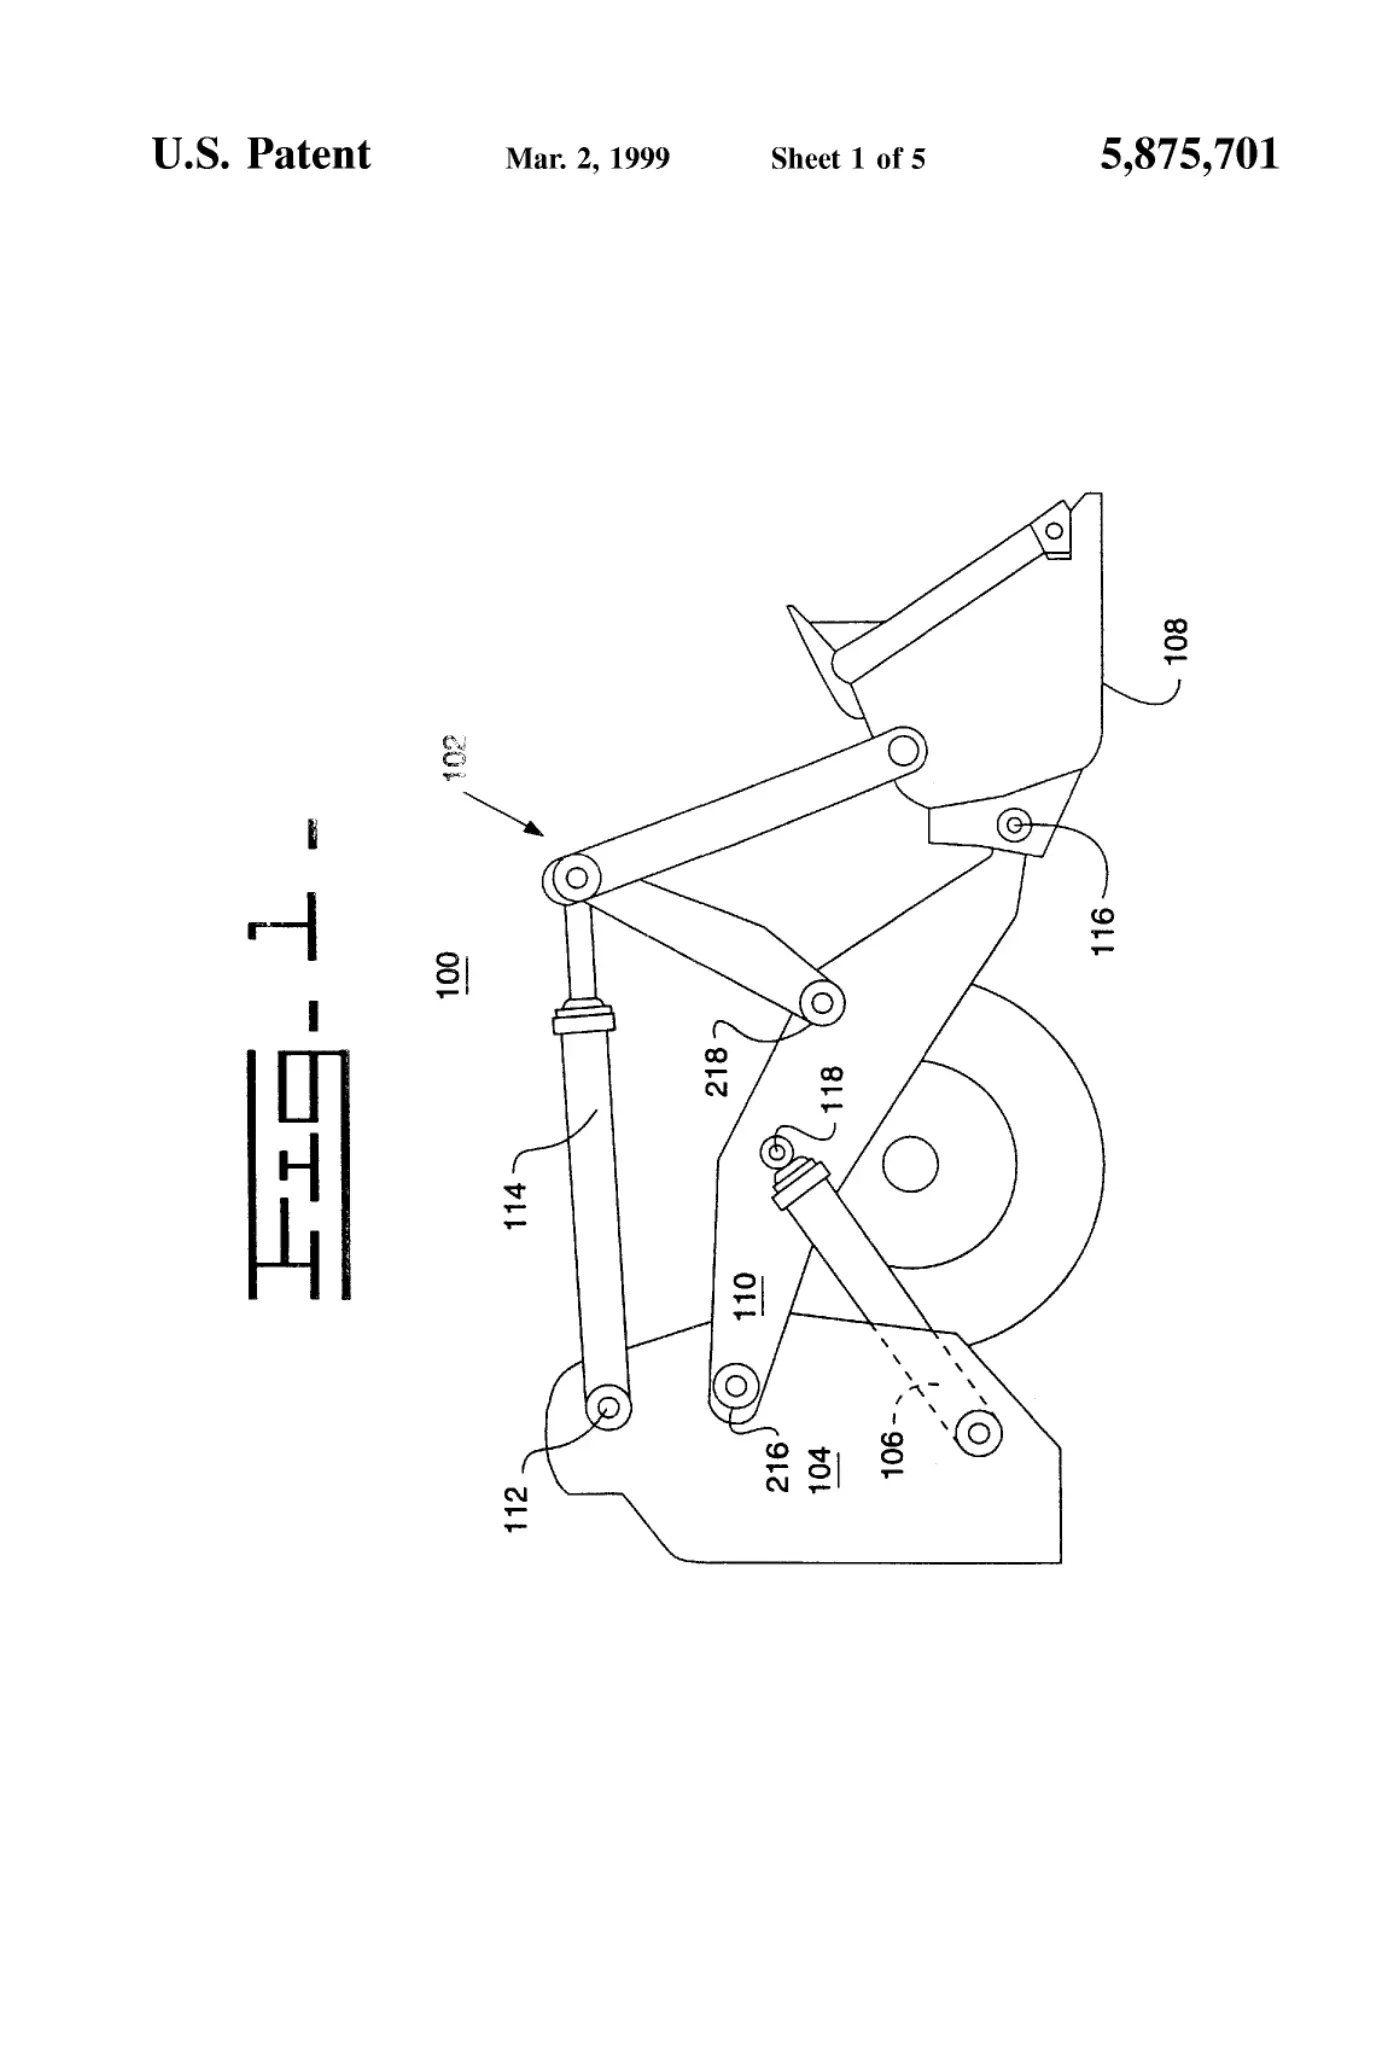
[0001]Sheet 1.
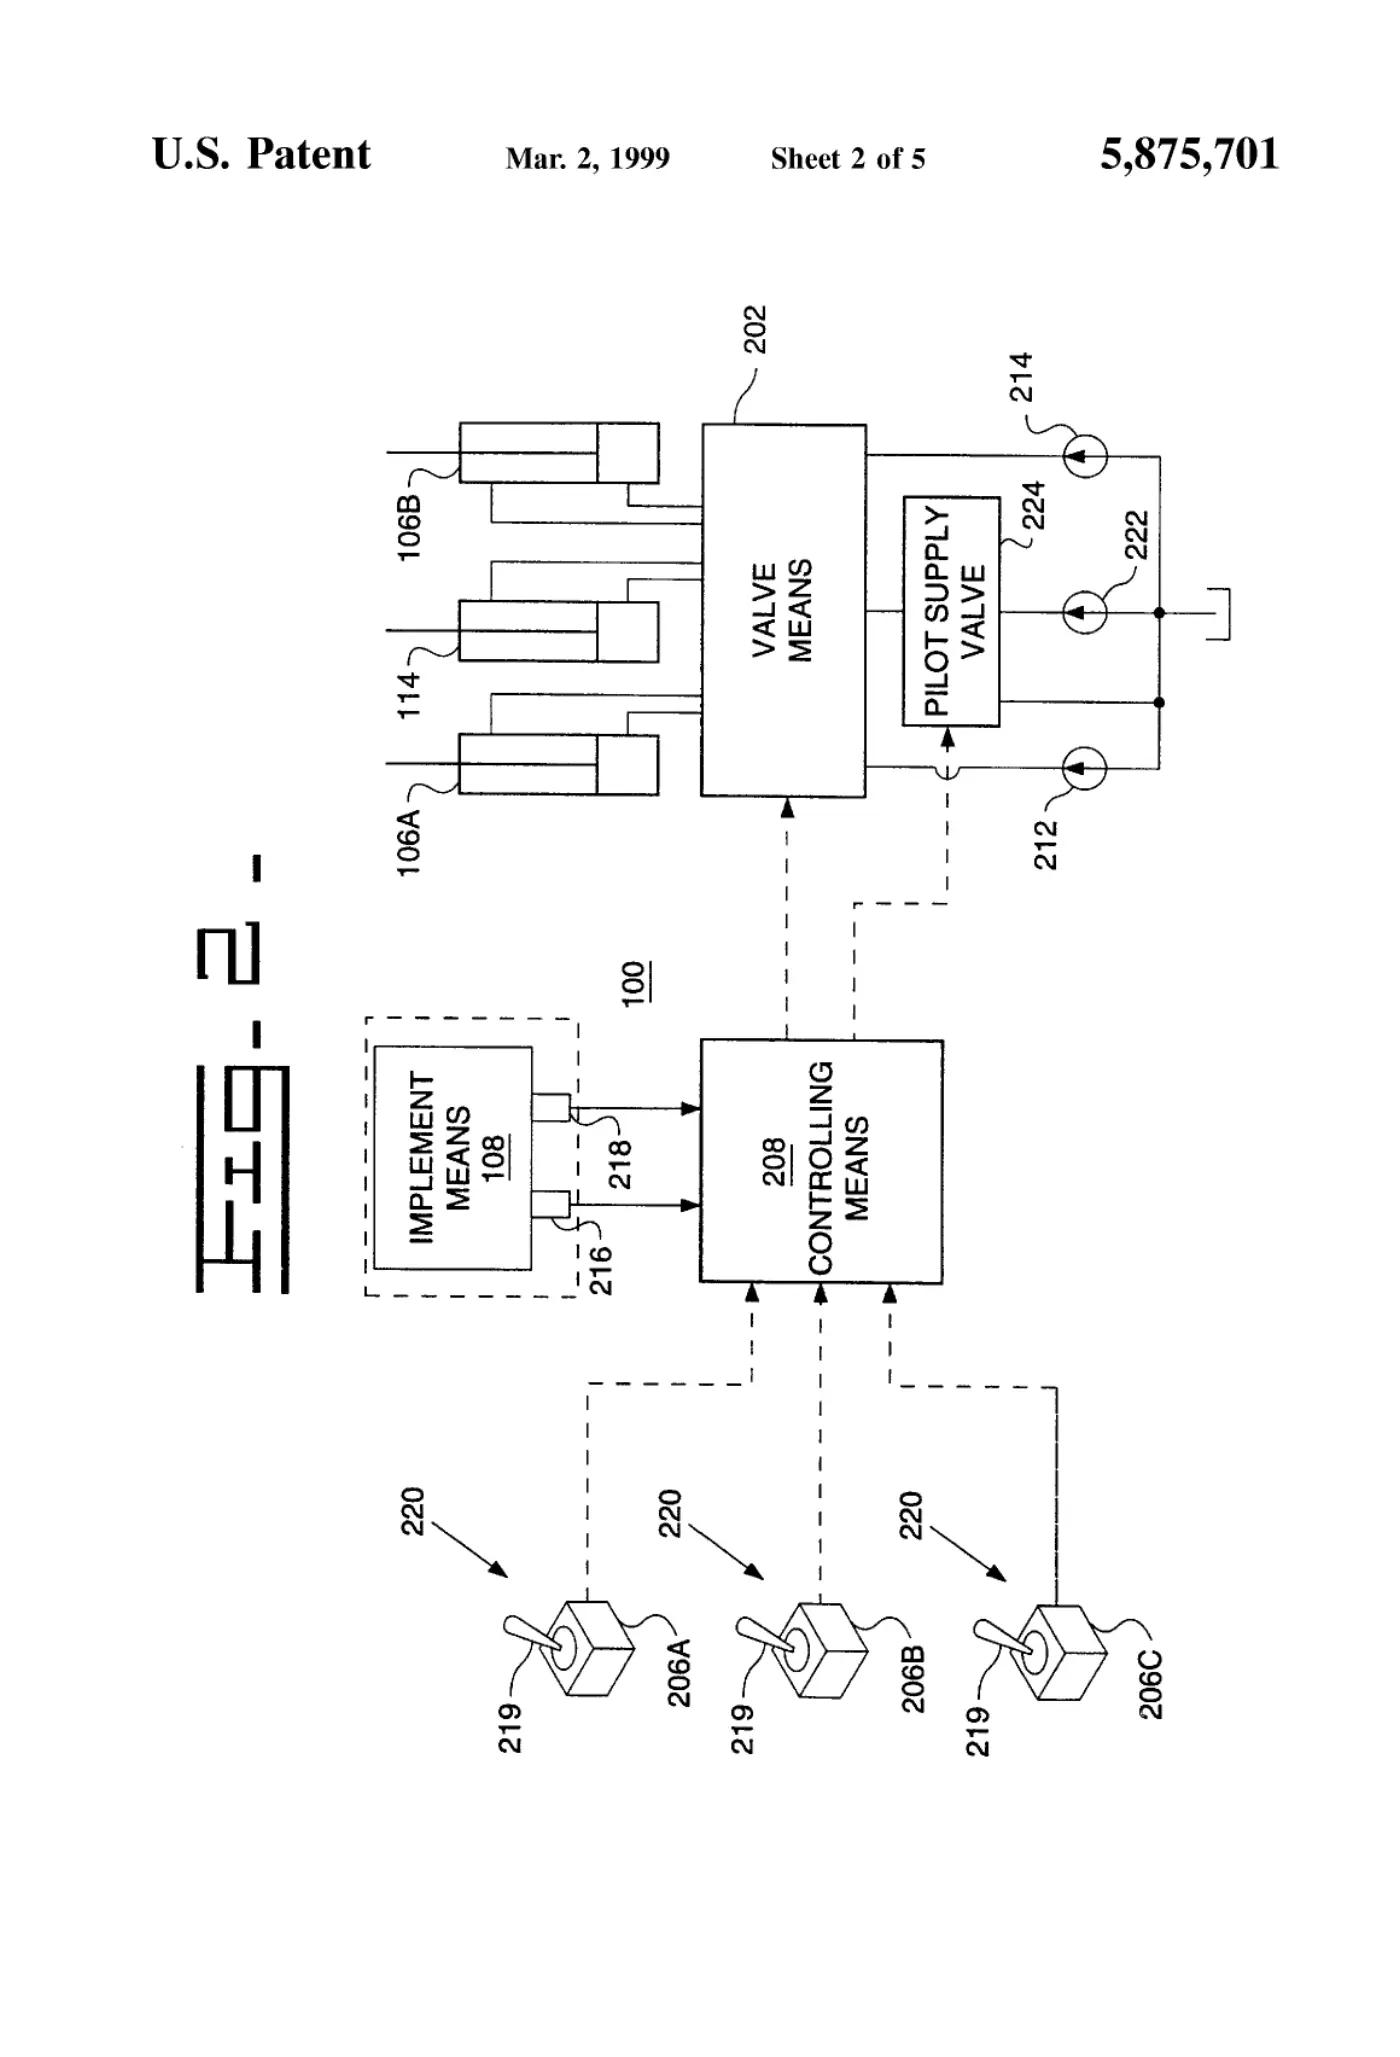
[0002]Sheet 2.
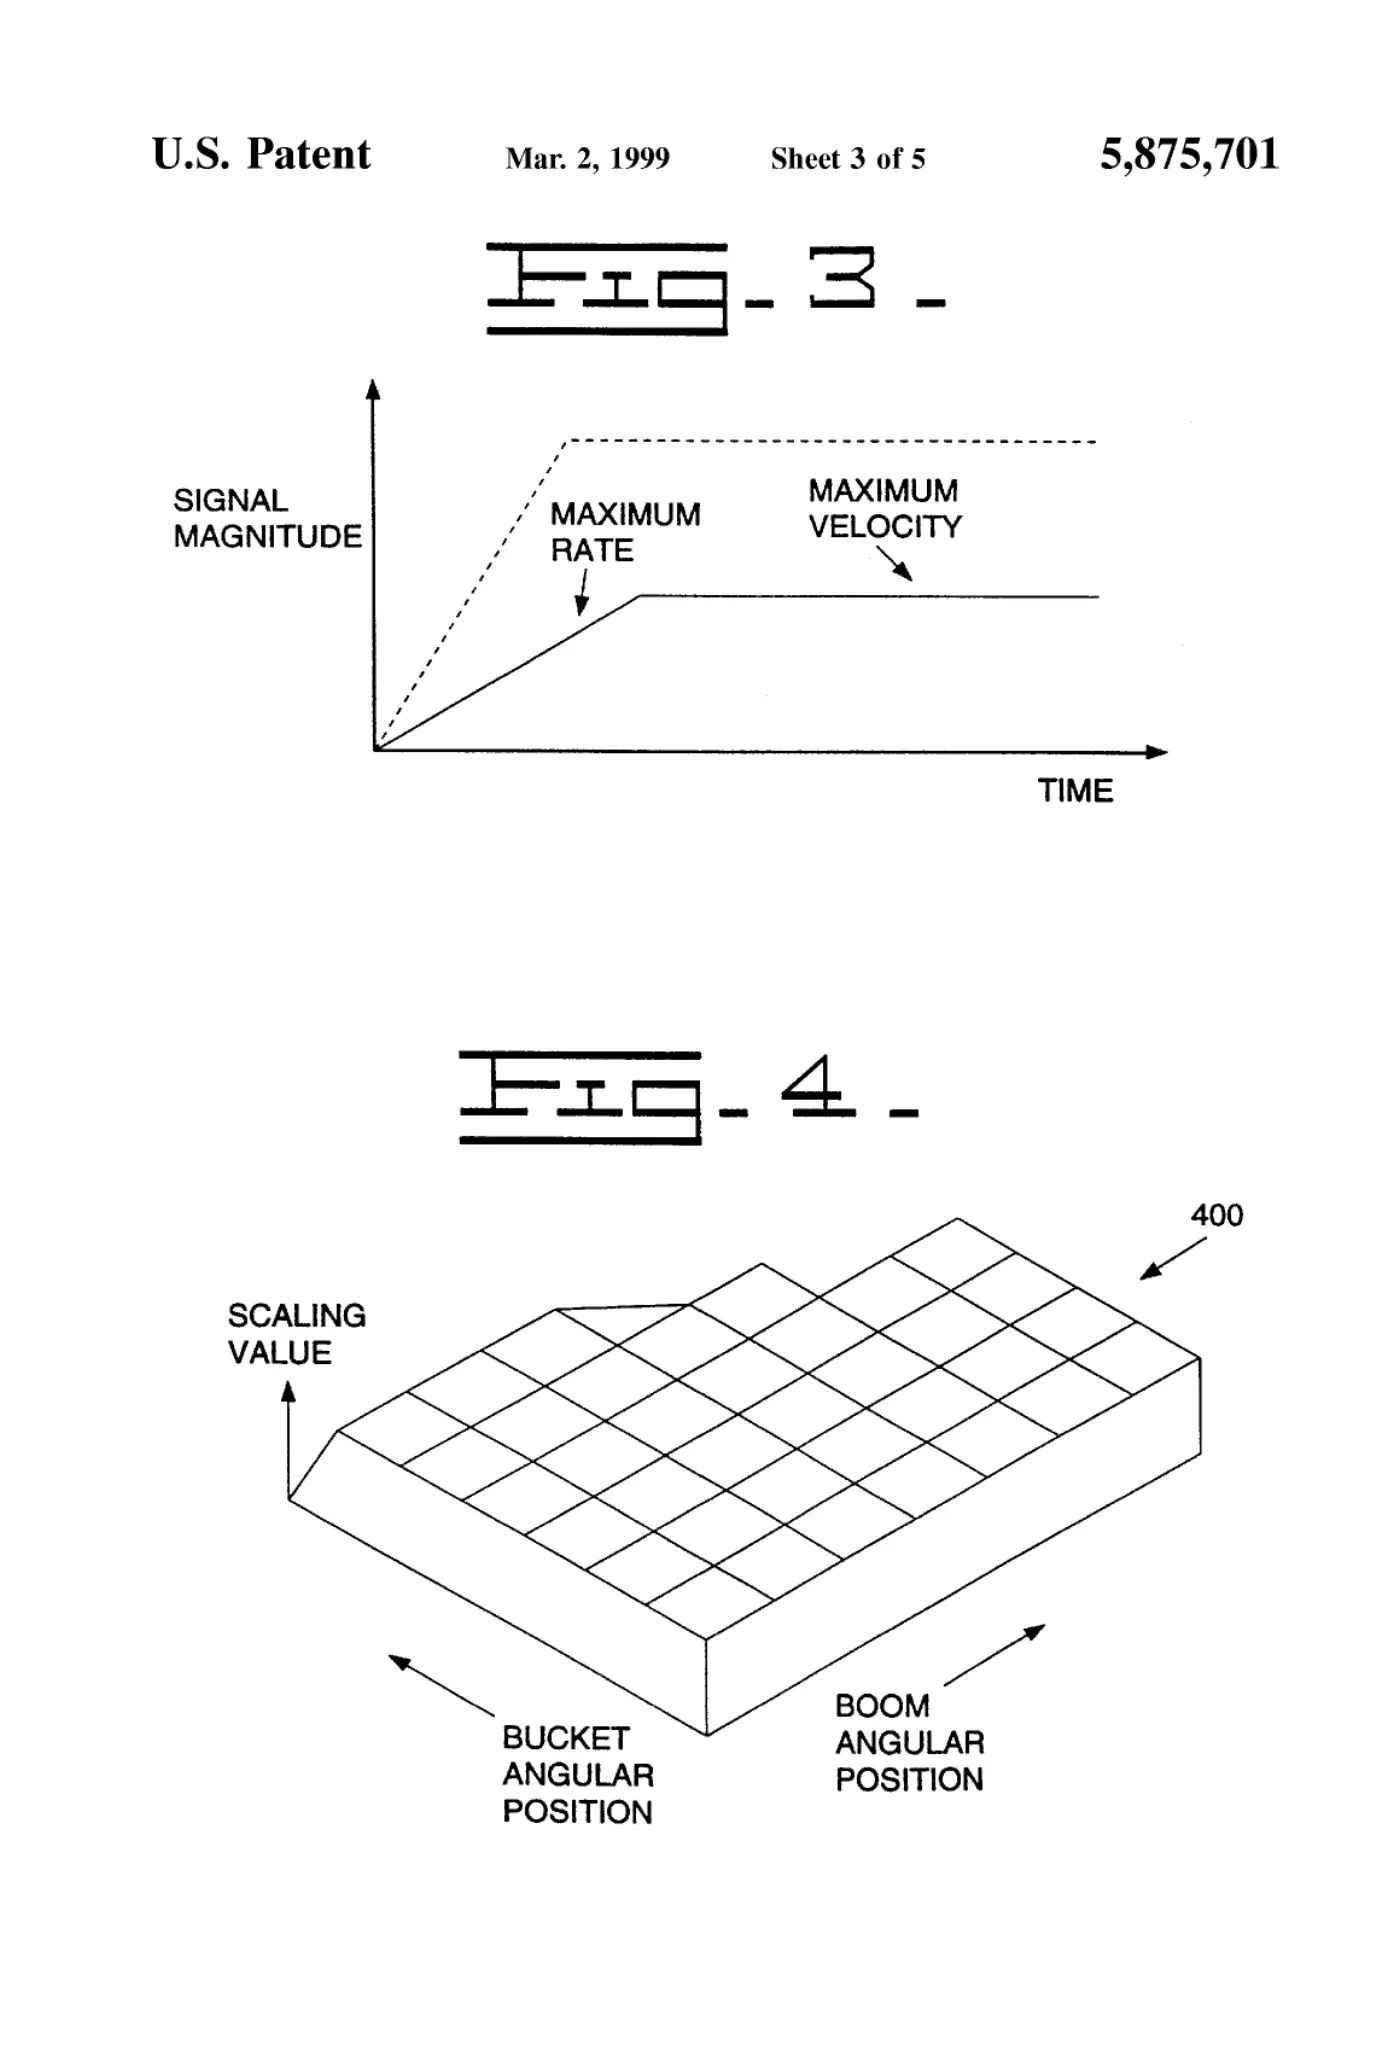
[0003]Sheet 3.
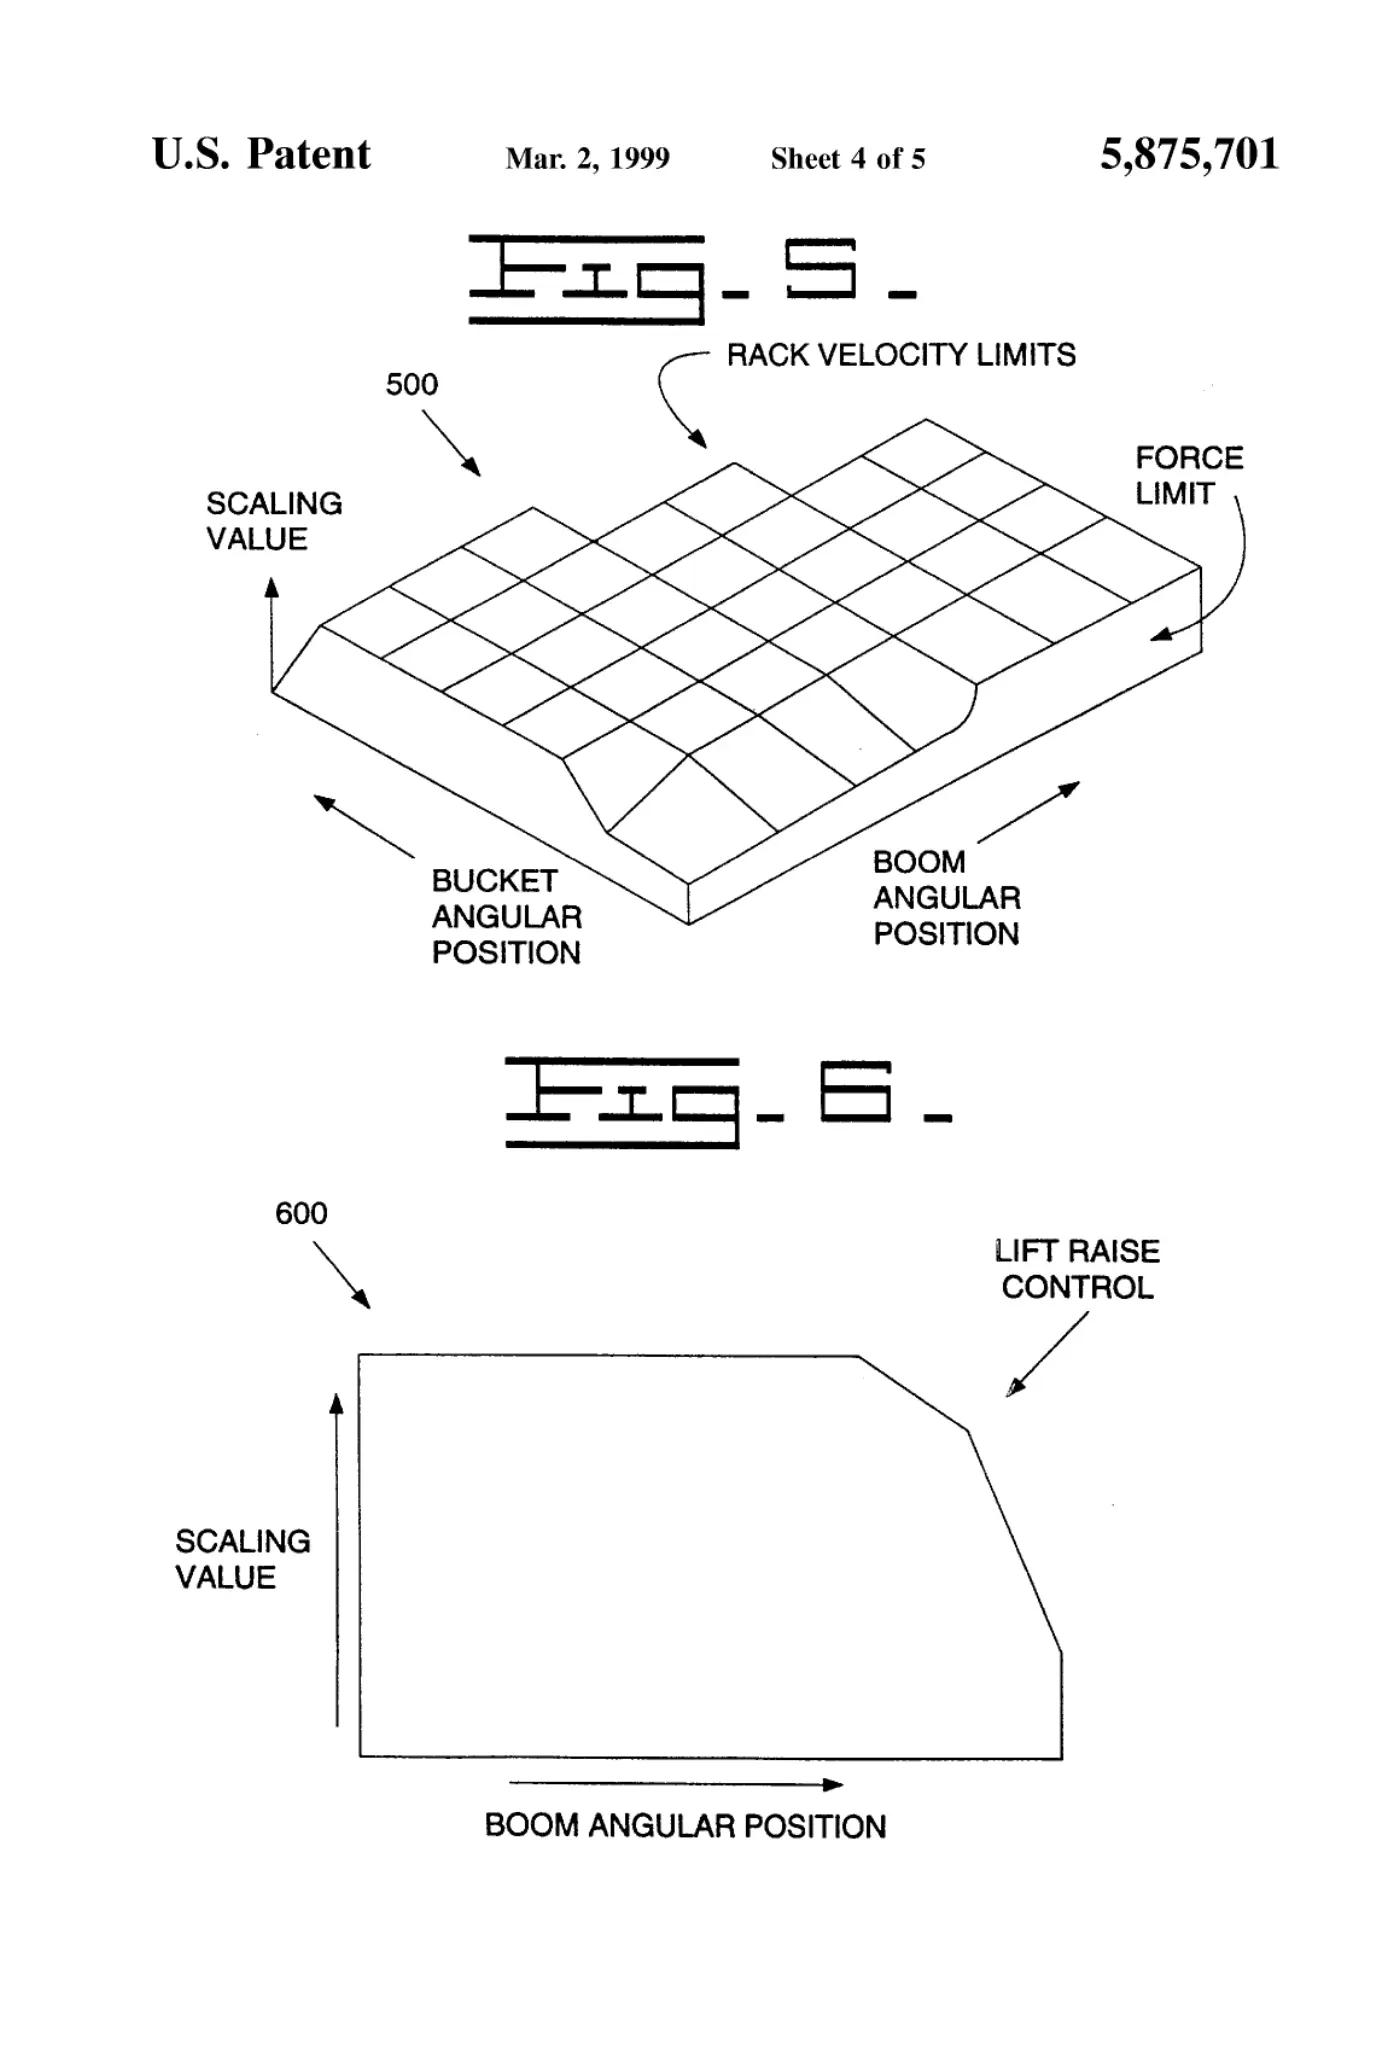
[0004]Sheet 4.
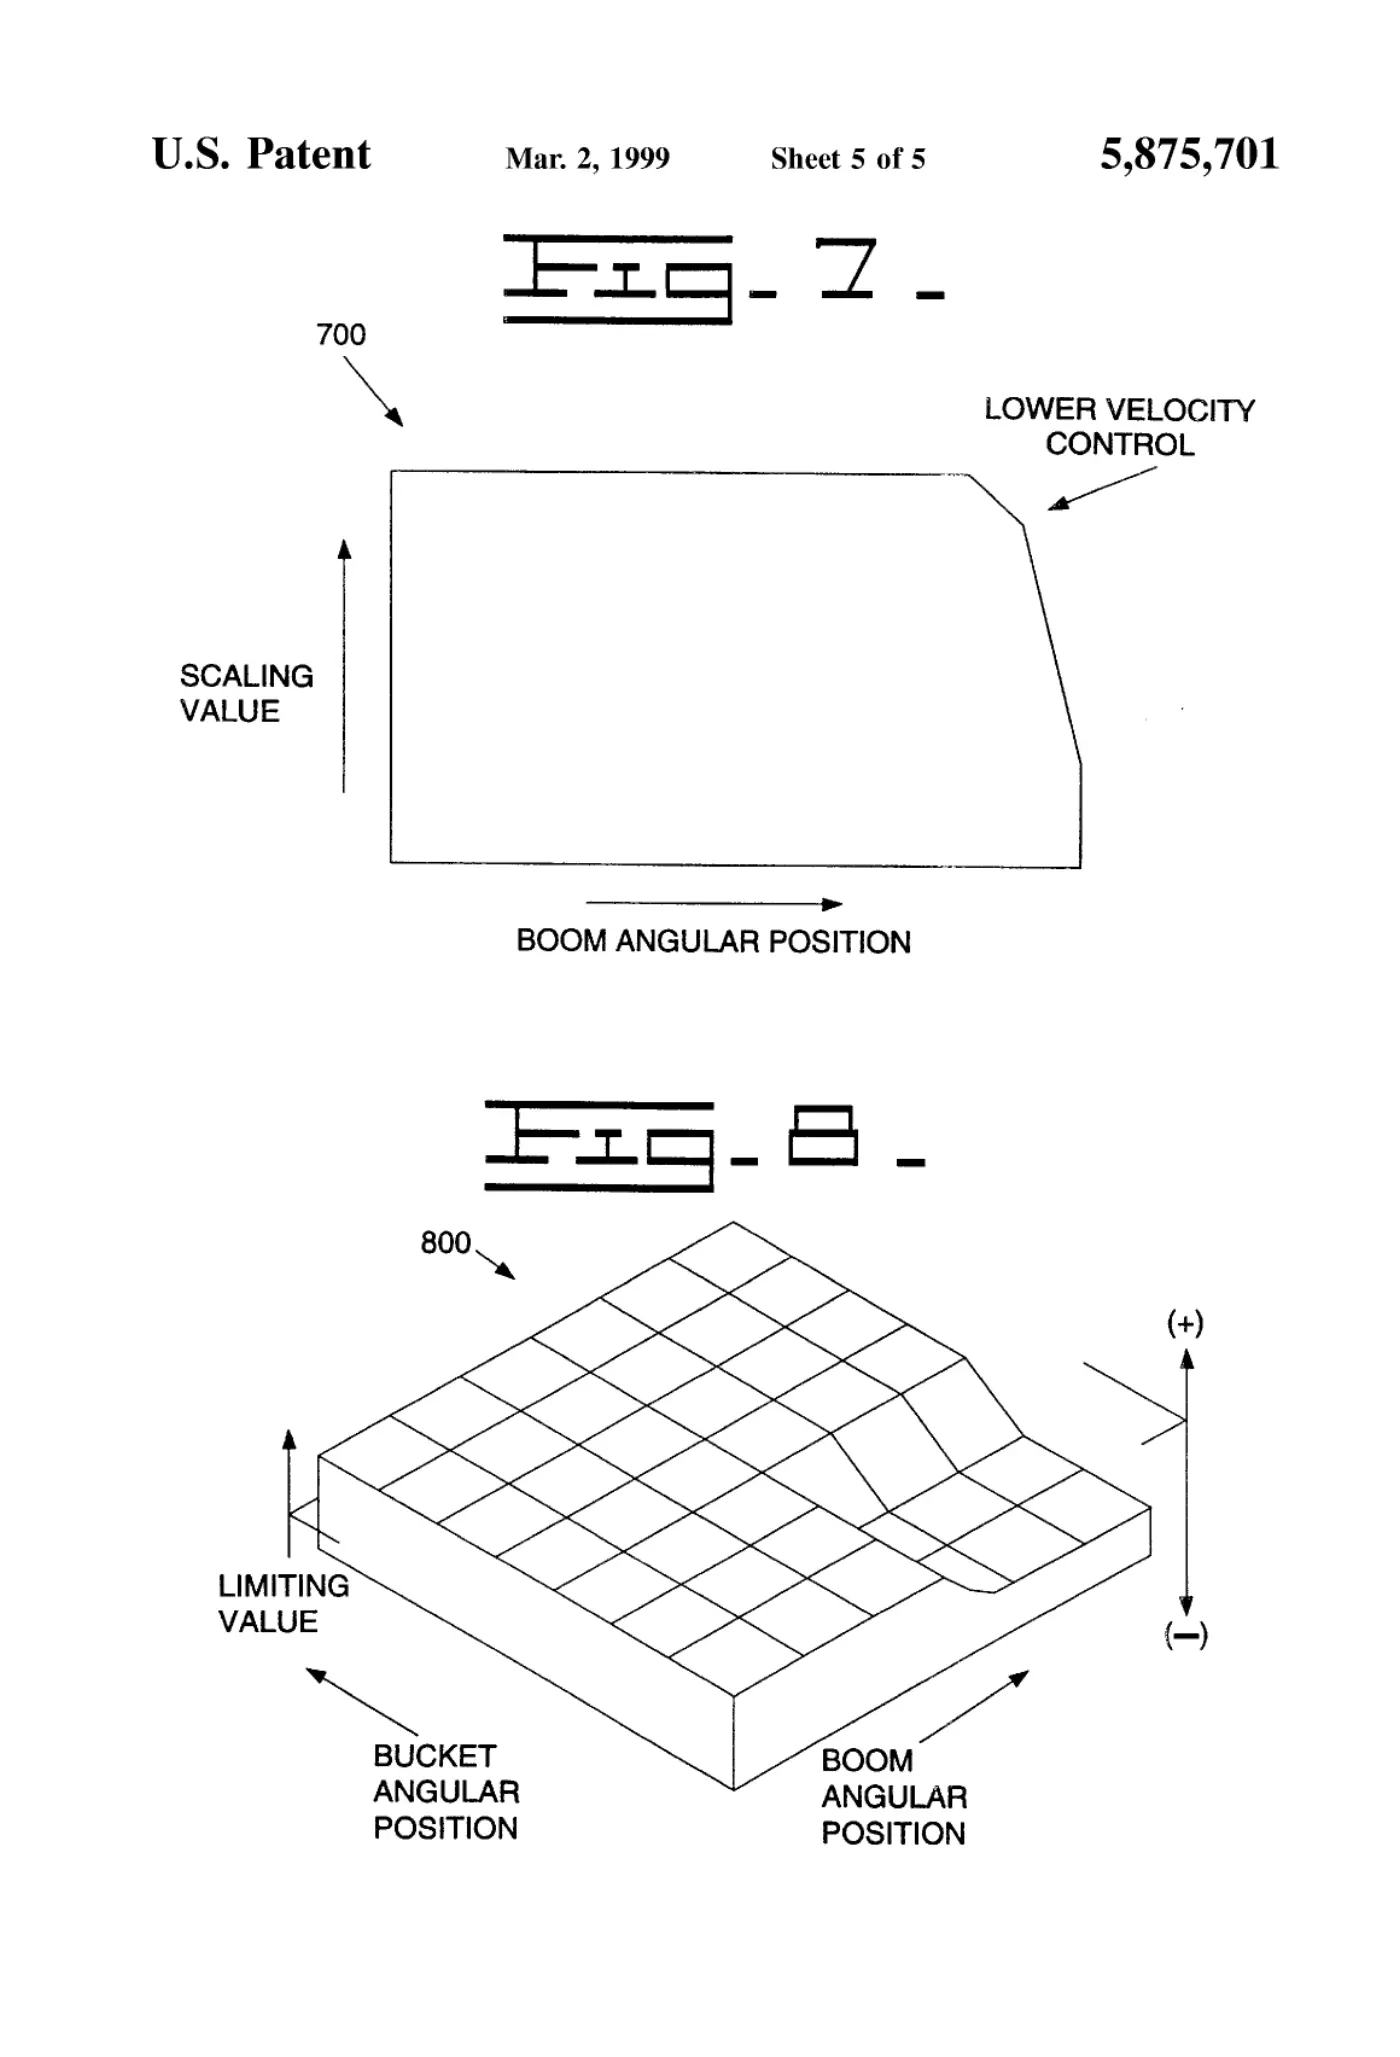
[0005]Sheet 5.
Publication information
Citation
OpenTechnical Publication OT-2026-000003193, “Method and apparatus for controlling an implement of a work machine using linkage angles,” published September 15, 2026 at 19:46:51 UTC, https://opentechnical.org/p/OT-2026-000003193.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.