OT-2026-000003194
Pneumatic grip
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003194
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- LIVSHITS DAVID
- Assignee
- ROBOTECH INC
- Original source
- US-5871814-A, the United States Patent and Trademark Office, 16 February 1999
- Document SHA-256
- c06d223a8bd615b8d4ef6a66c889988754b385a77a08f97c06ec7b1c9b6ee51e
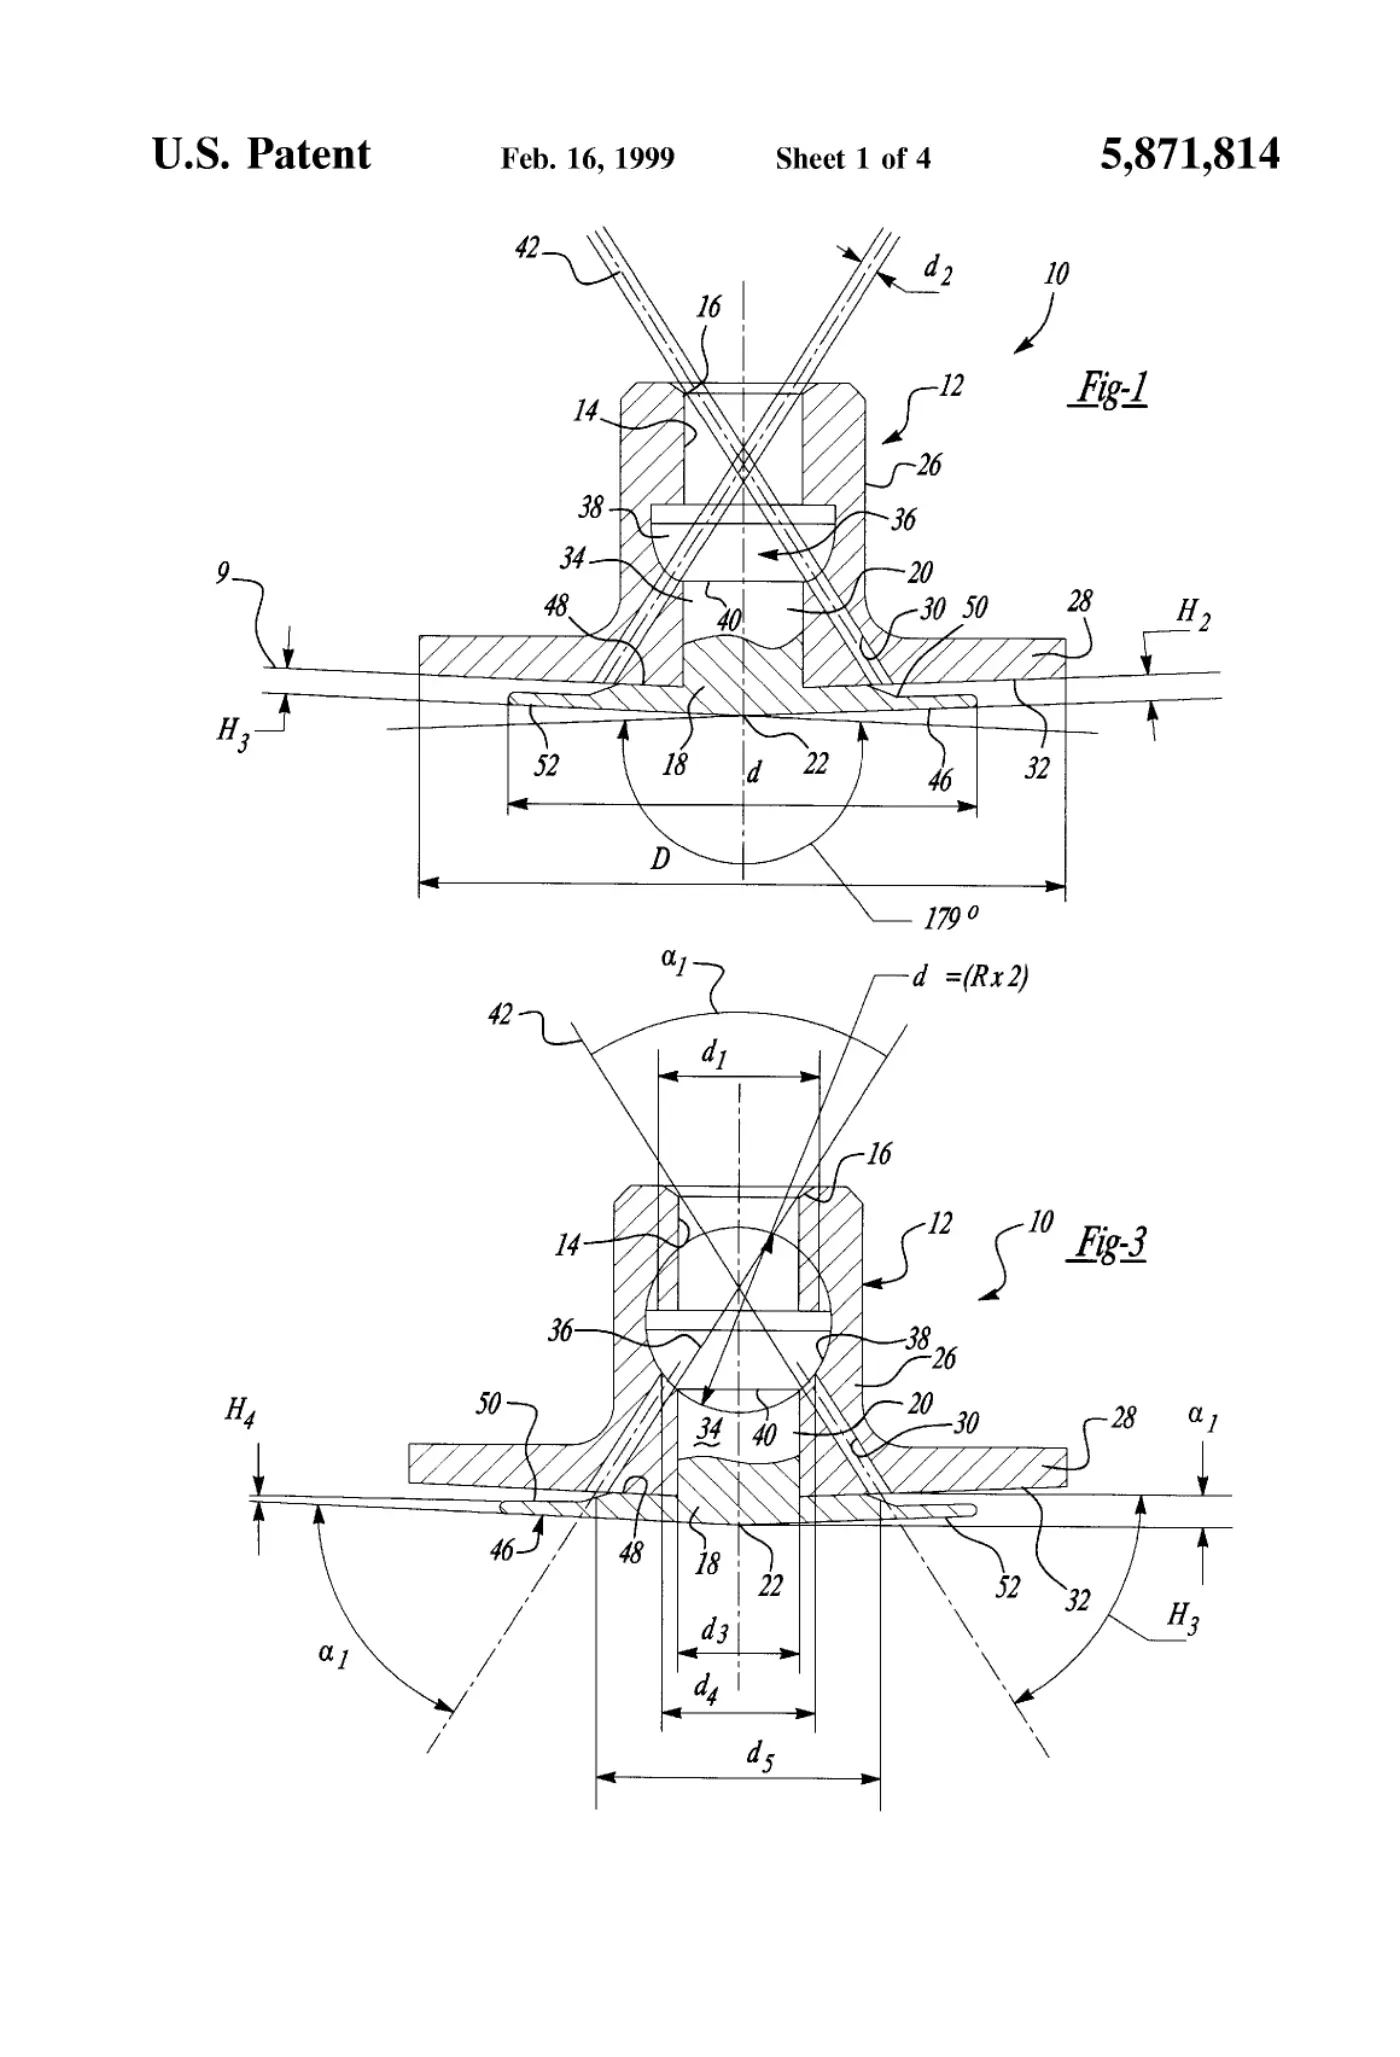
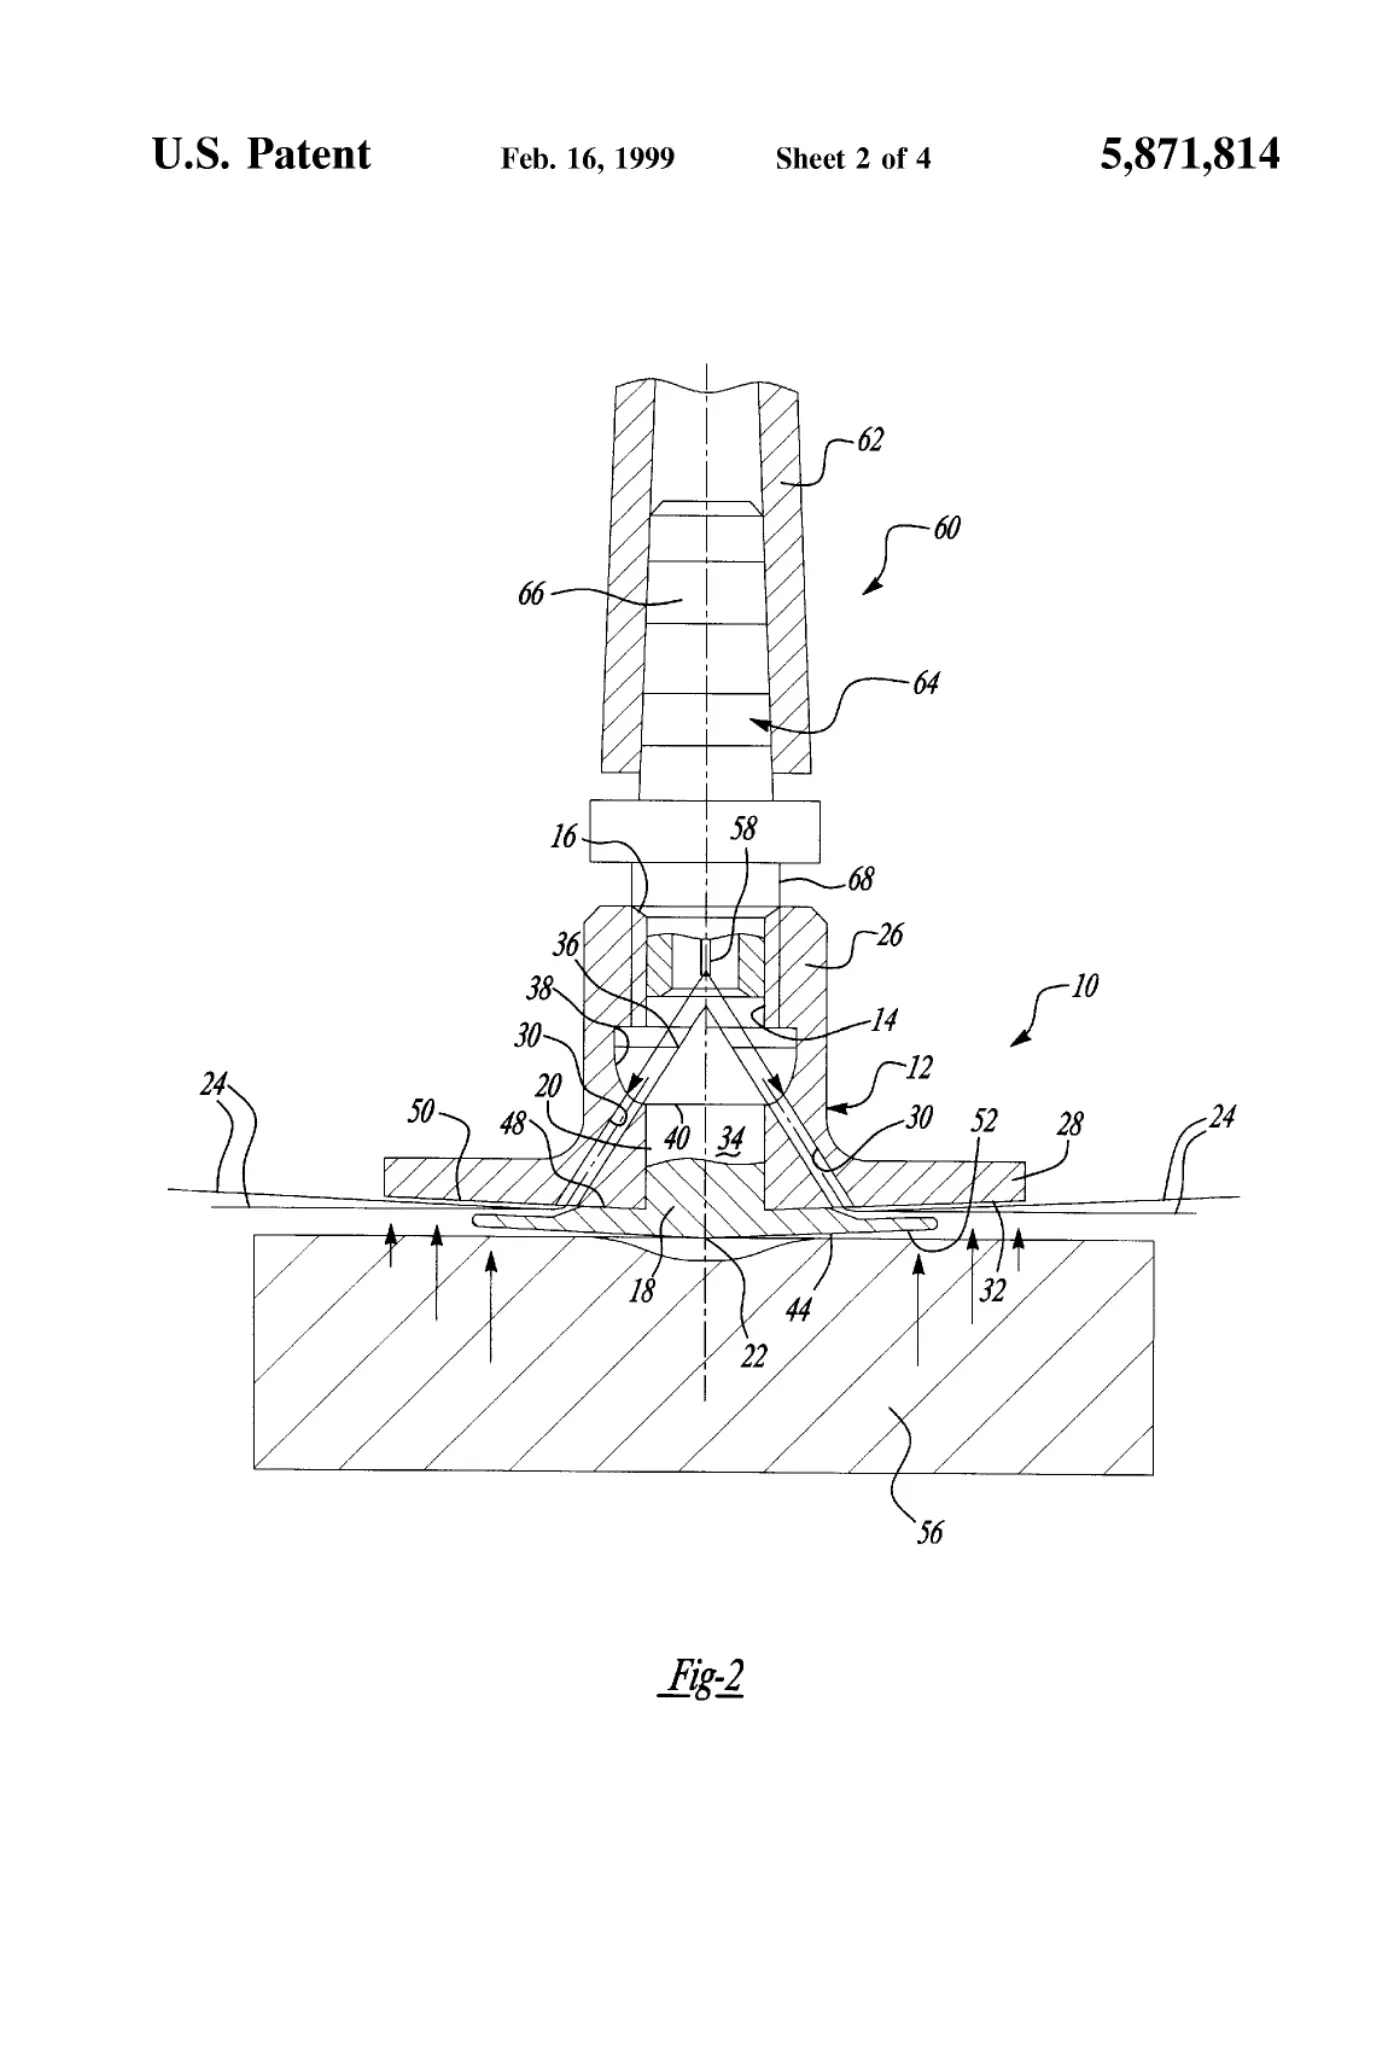
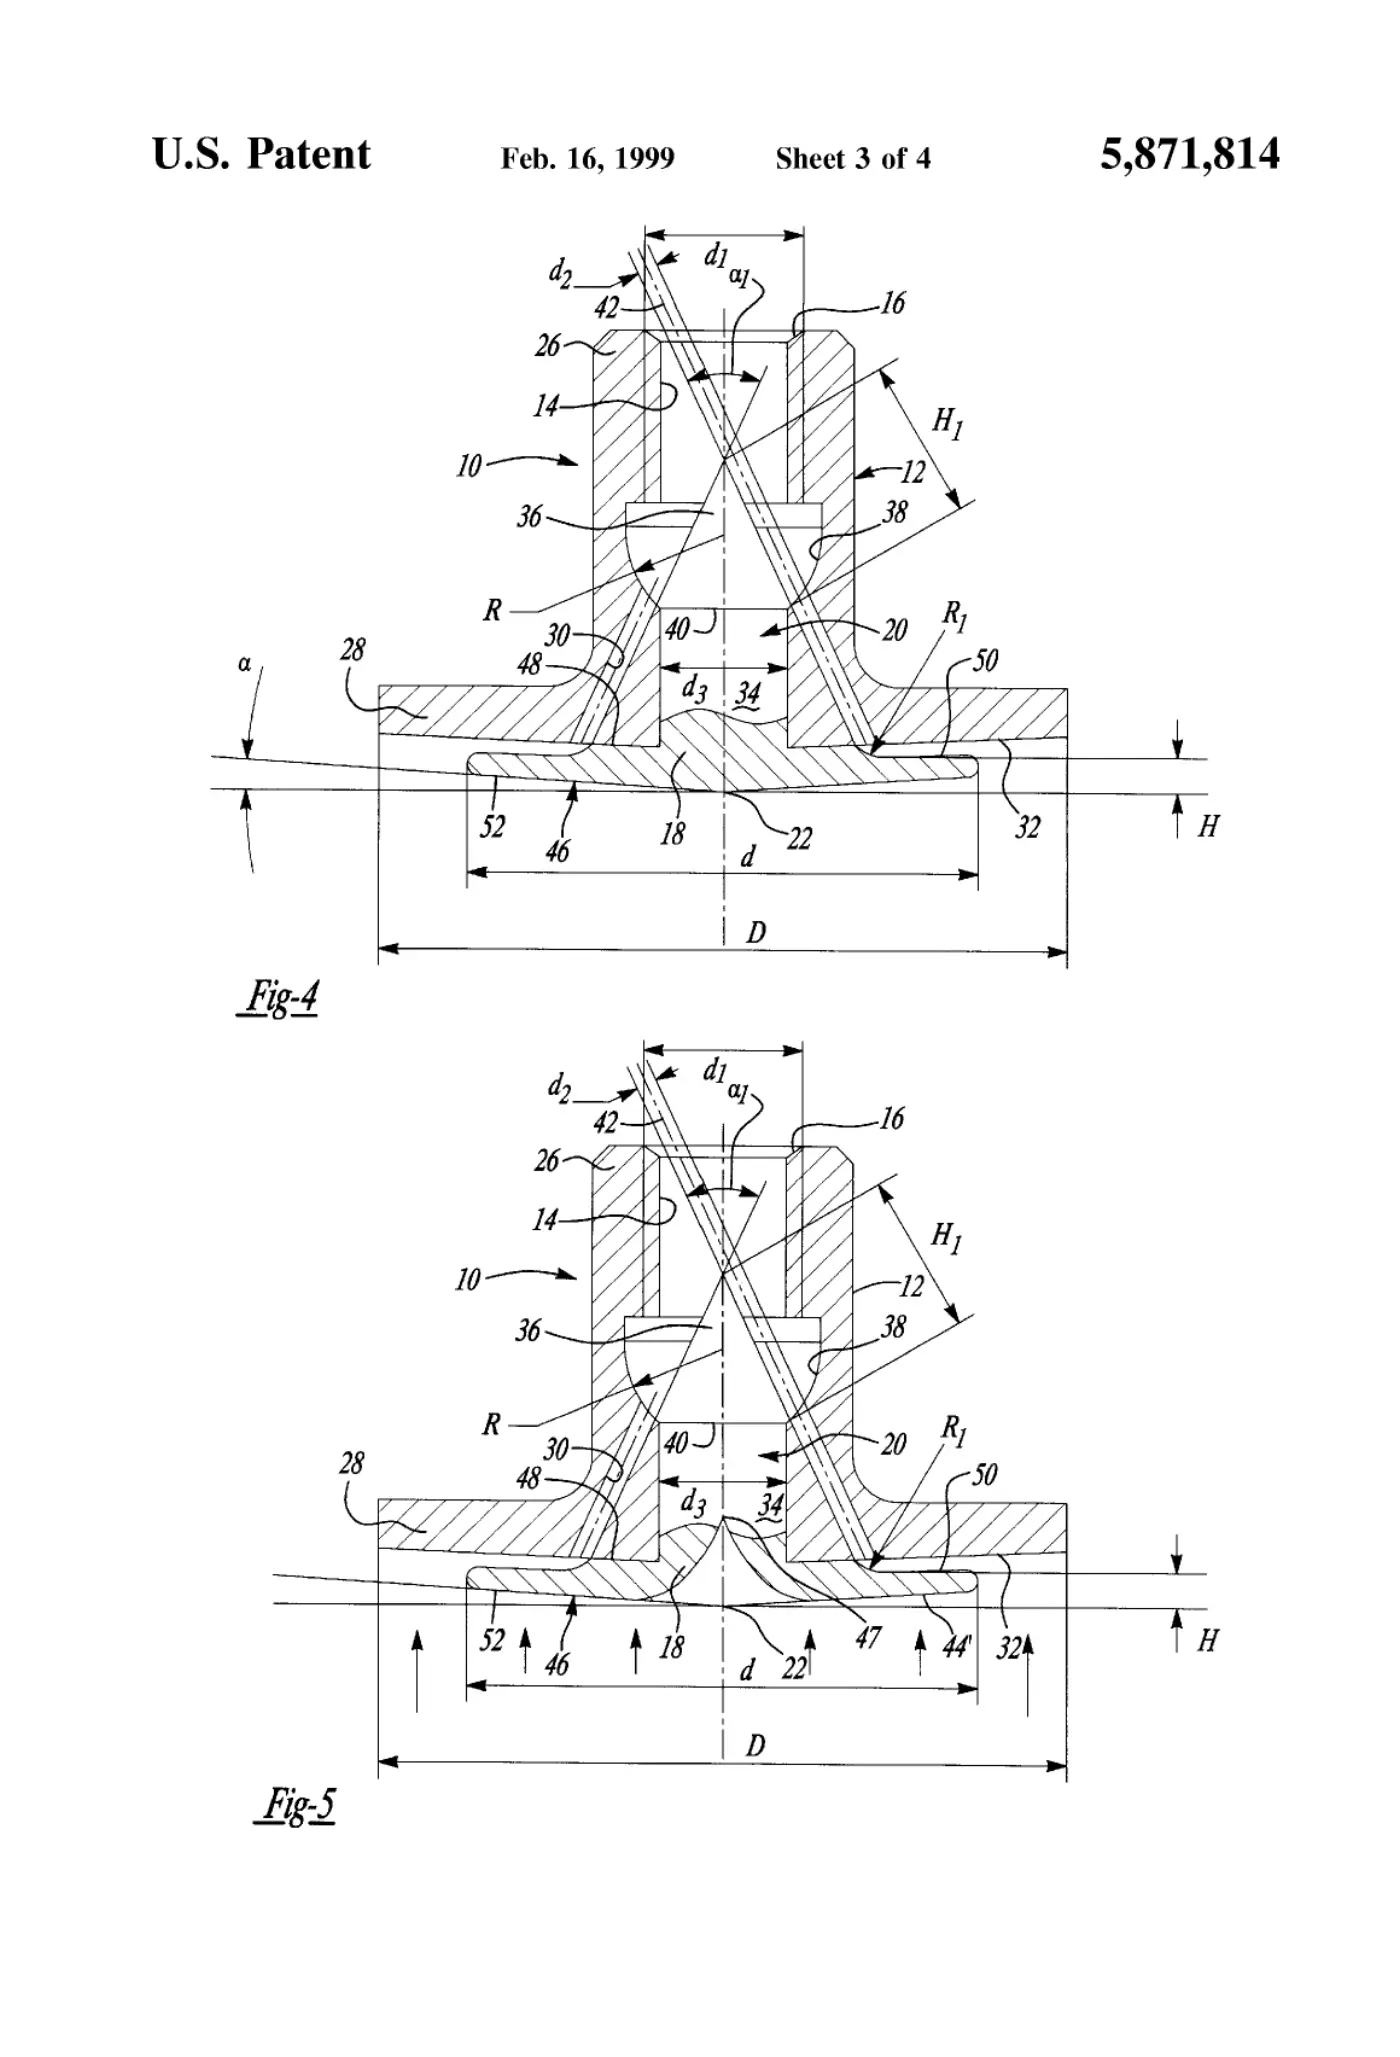
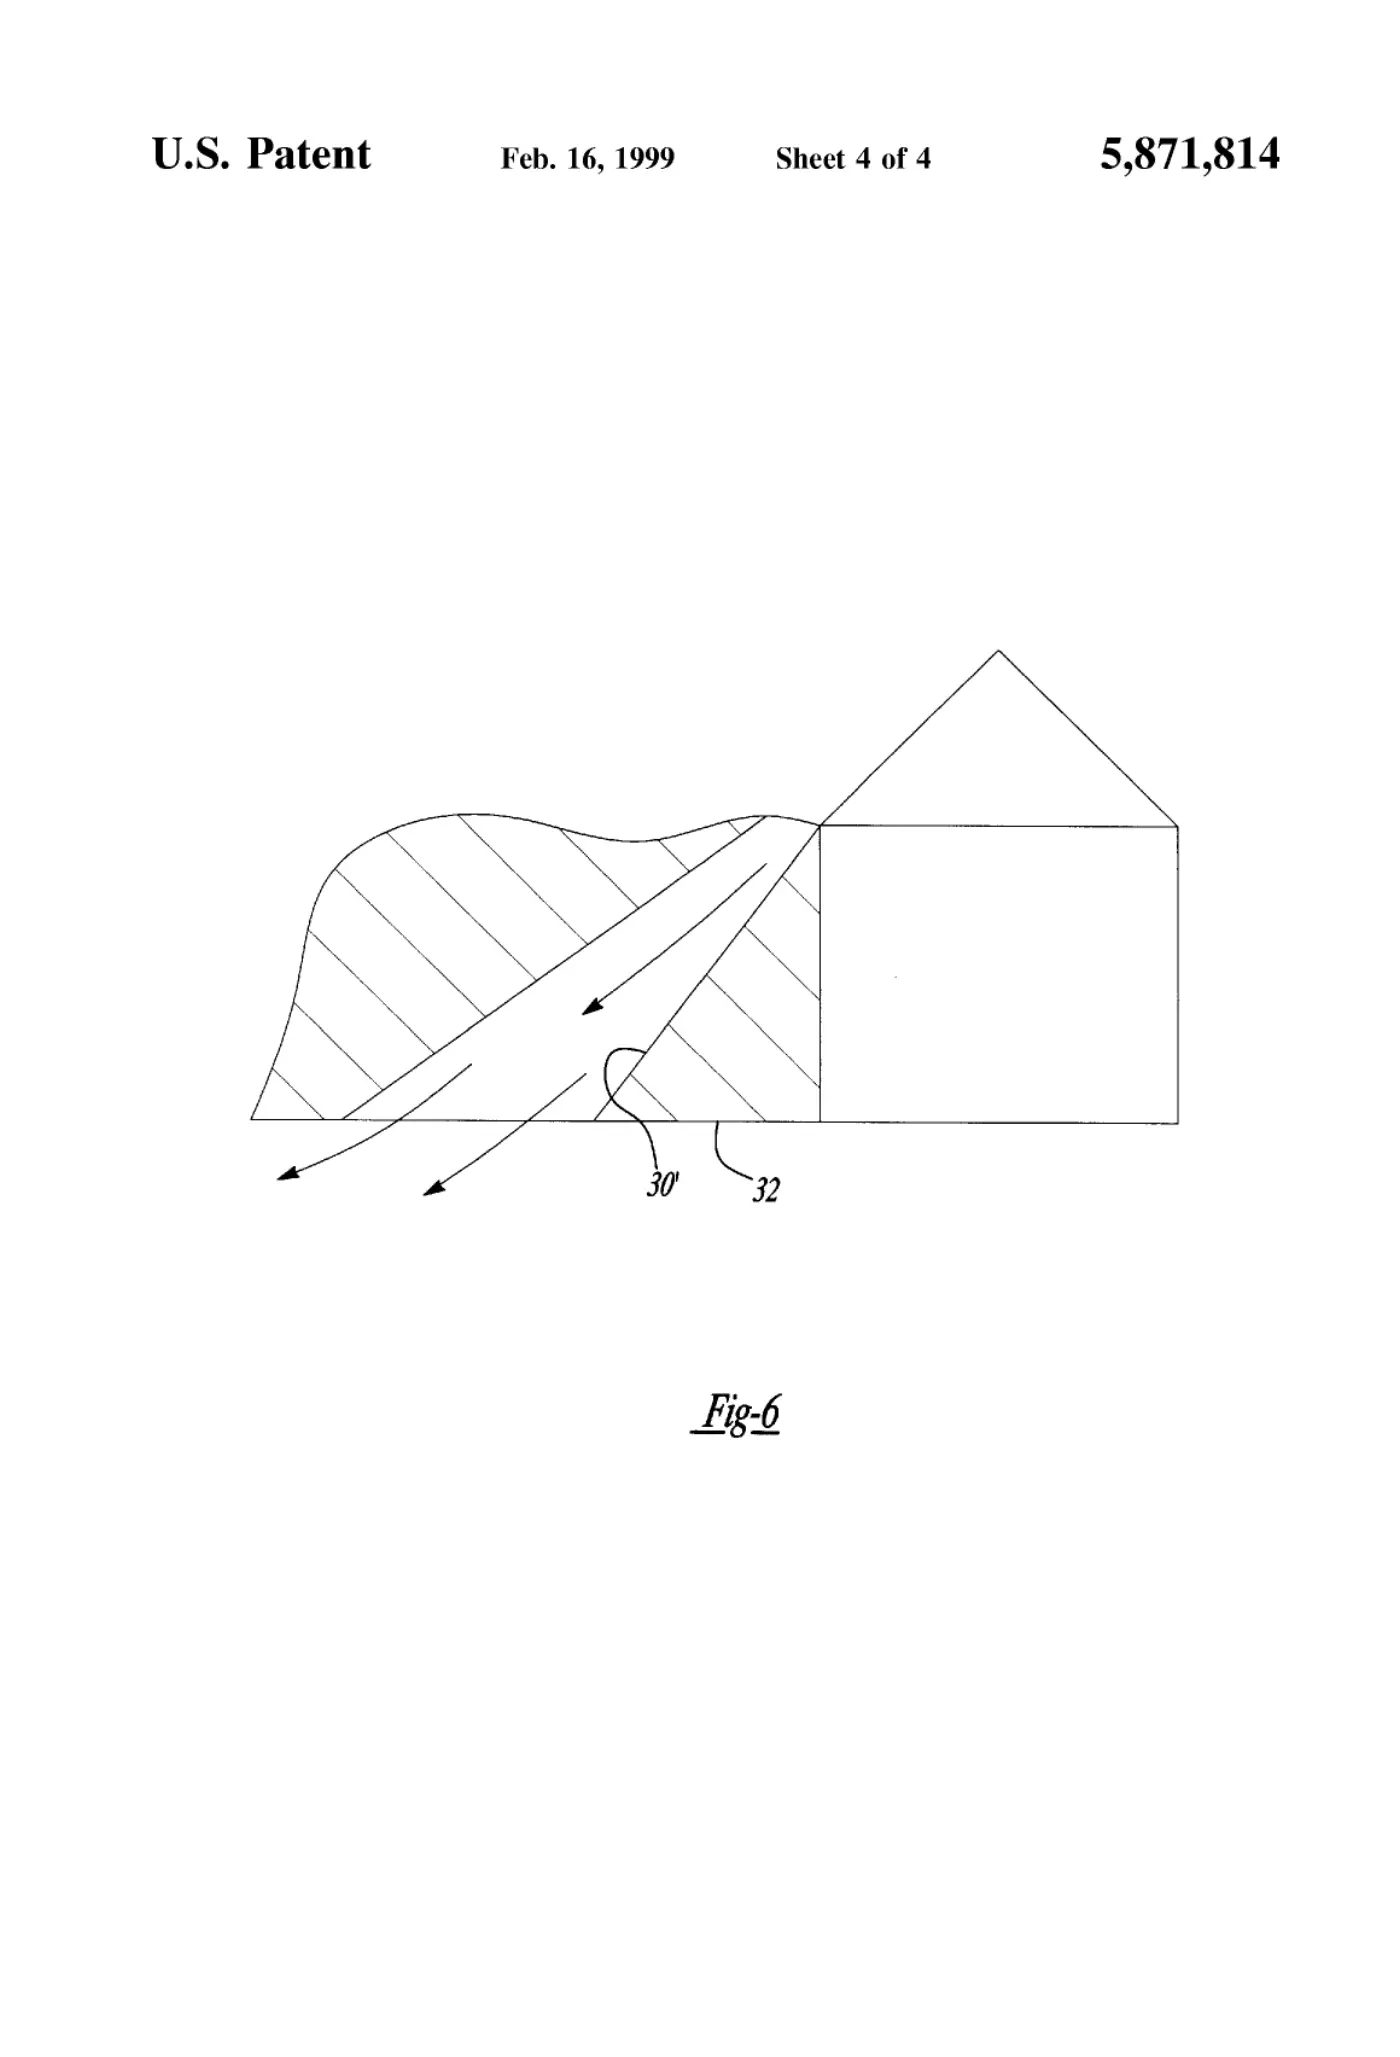
A device for shaping a vacuum includes a housing having a primary passageway which includes an inlet. A fluid shaping mechanism is disposed in the primary passageway in fluid communication with the inlet for changing the shape of a fluid flow into a planar fluid flow flowing radially outwardly from a central point. The fluid shaping mechanism includes a conically-shaped portion disposed within the primary passageway, a plurality of secondary passageways extending through the housing from a periphery of the cone-shaped surface to outlets at a bottom surface of the housing, and a reflector adjacent to and spaced from the bottom surface for uniformly reflecting the fluid from the secondary passageways radially outwardly to create a vacuum adjacent thereto.
Abstract
A device for shaping a vacuum includes a housing having a primary passageway which includes an inlet. A fluid shaping mechanism is disposed in the primary passageway in fluid communication with the inlet for changing the shape of a fluid flow into a planar fluid flow flowing radially outwardly from a central point. The fluid shaping mechanism includes a conically-shaped portion disposed within the primary passageway, a plurality of secondary passageways extending through the housing from a periphery of the cone-shaped surface to outlets at a bottom surface of the housing, and a reflector adjacent to and spaced from the bottom surface for uniformly reflecting the fluid from the secondary passageways radially outwardly to create a vacuum adjacent thereto.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
Publication information
Citation
OpenTechnical Publication OT-2026-000003194, “Pneumatic grip,” published September 15, 2026 at 19:46:58 UTC, https://opentechnical.org/p/OT-2026-000003194.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.