OT-2026-000003217
Hydraulic boom platform leveling system
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003217
- Classification
- Lifting, Positioning & Manipulation › Lift Tables and Positioners
- Inventors
- MLAKER JOHN J
- Assignee
- MAT 3 INC
- Original source
- US-5746286-A, the United States Patent and Trademark Office, 5 May 1998
- Document SHA-256
- 7b1c0aca9d536865e246a115a793d955f779f57008c0fad82b9a593fc2cfbe7e
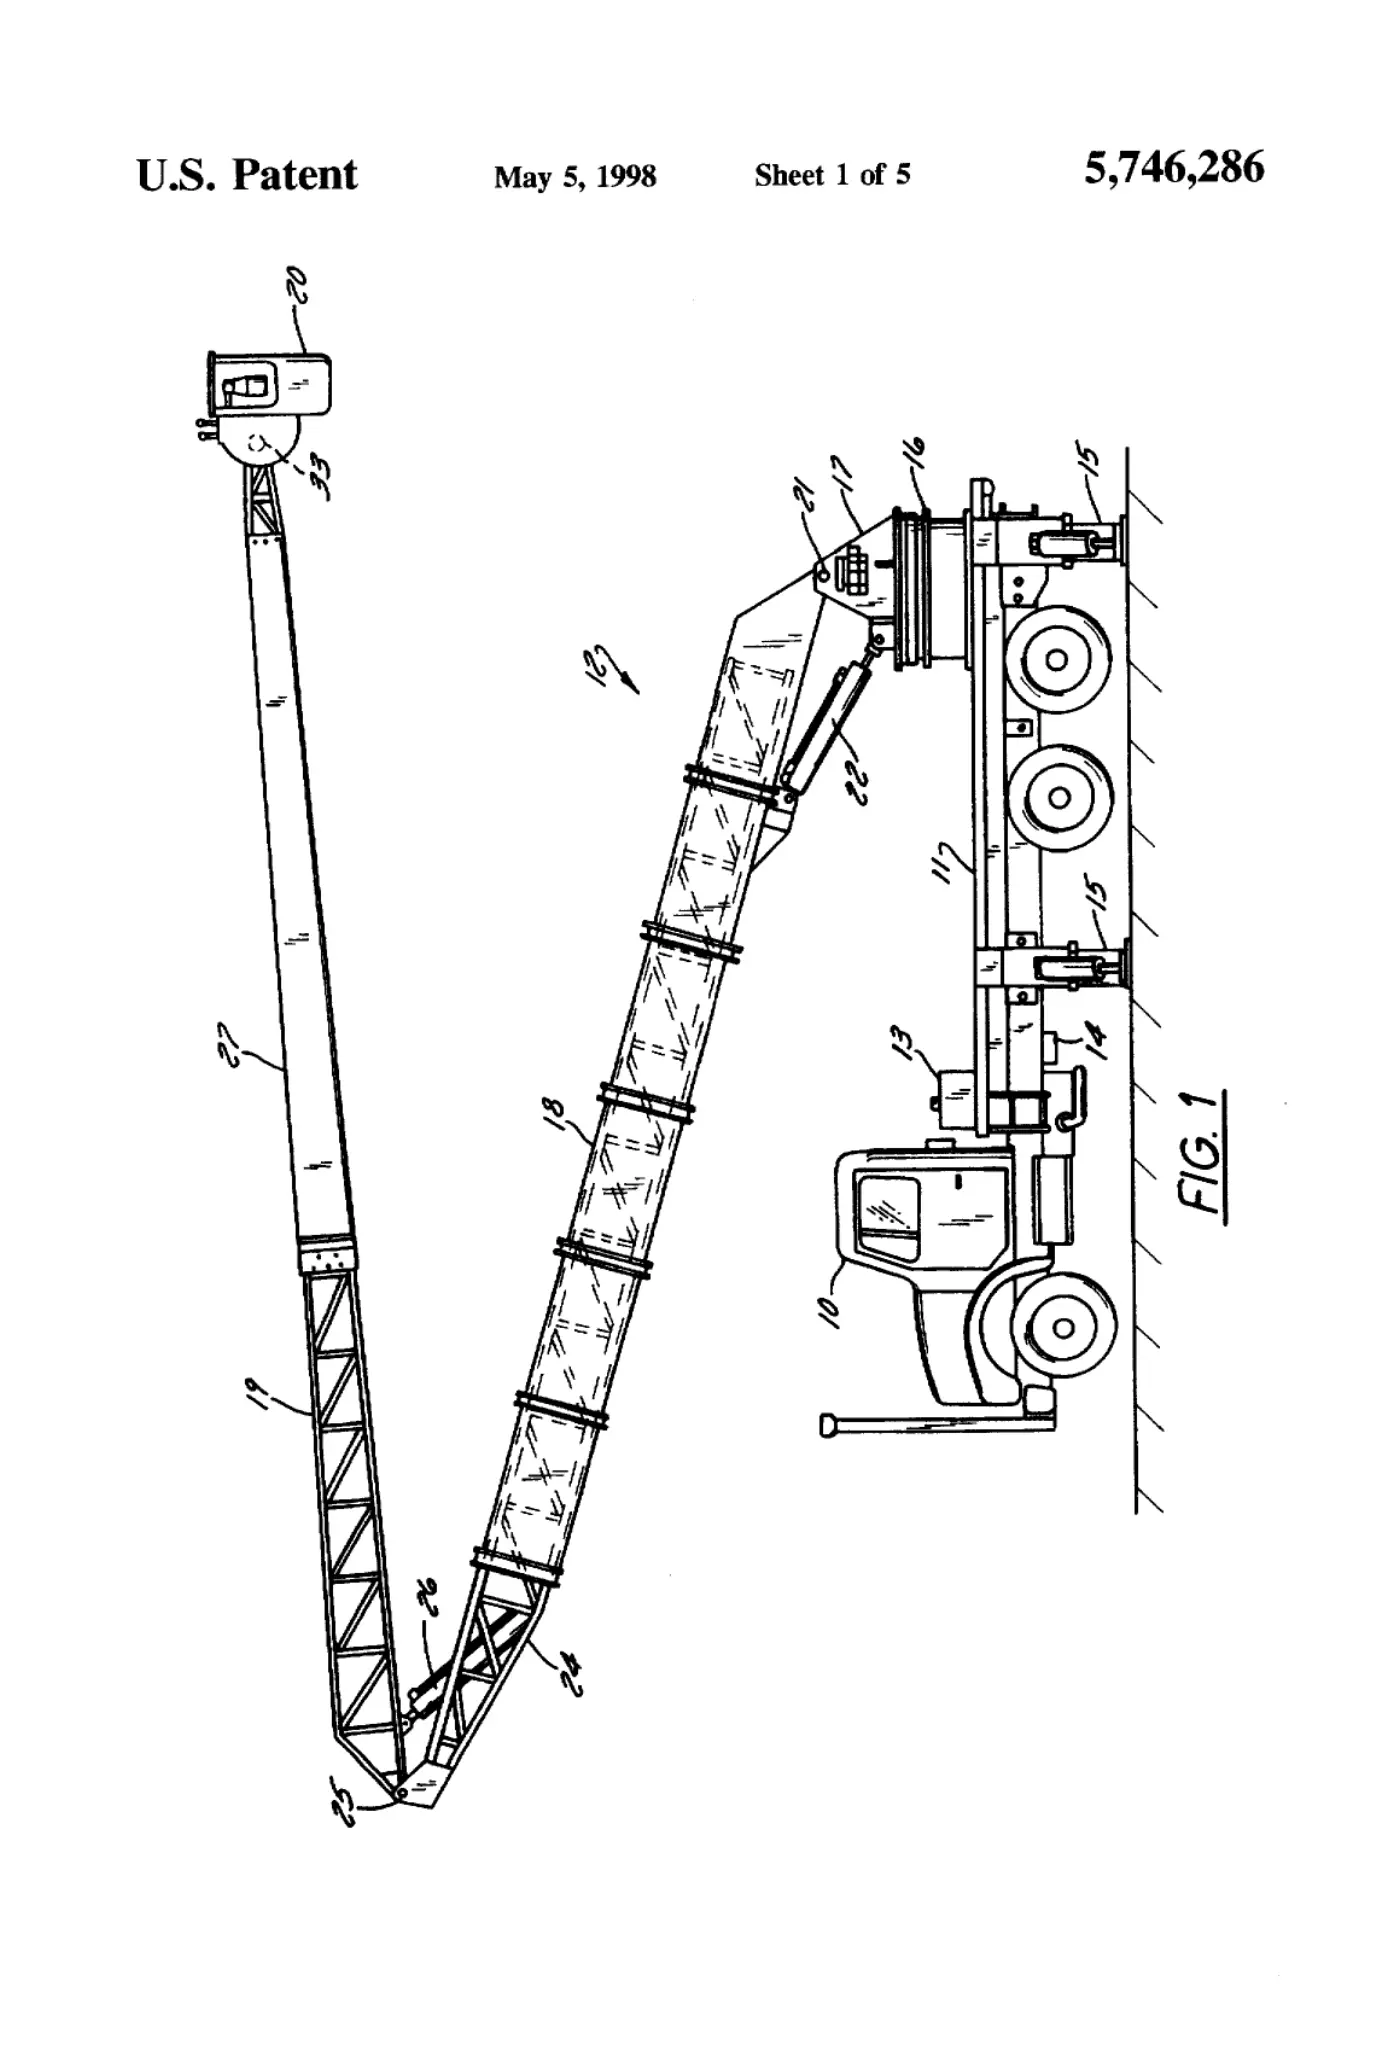
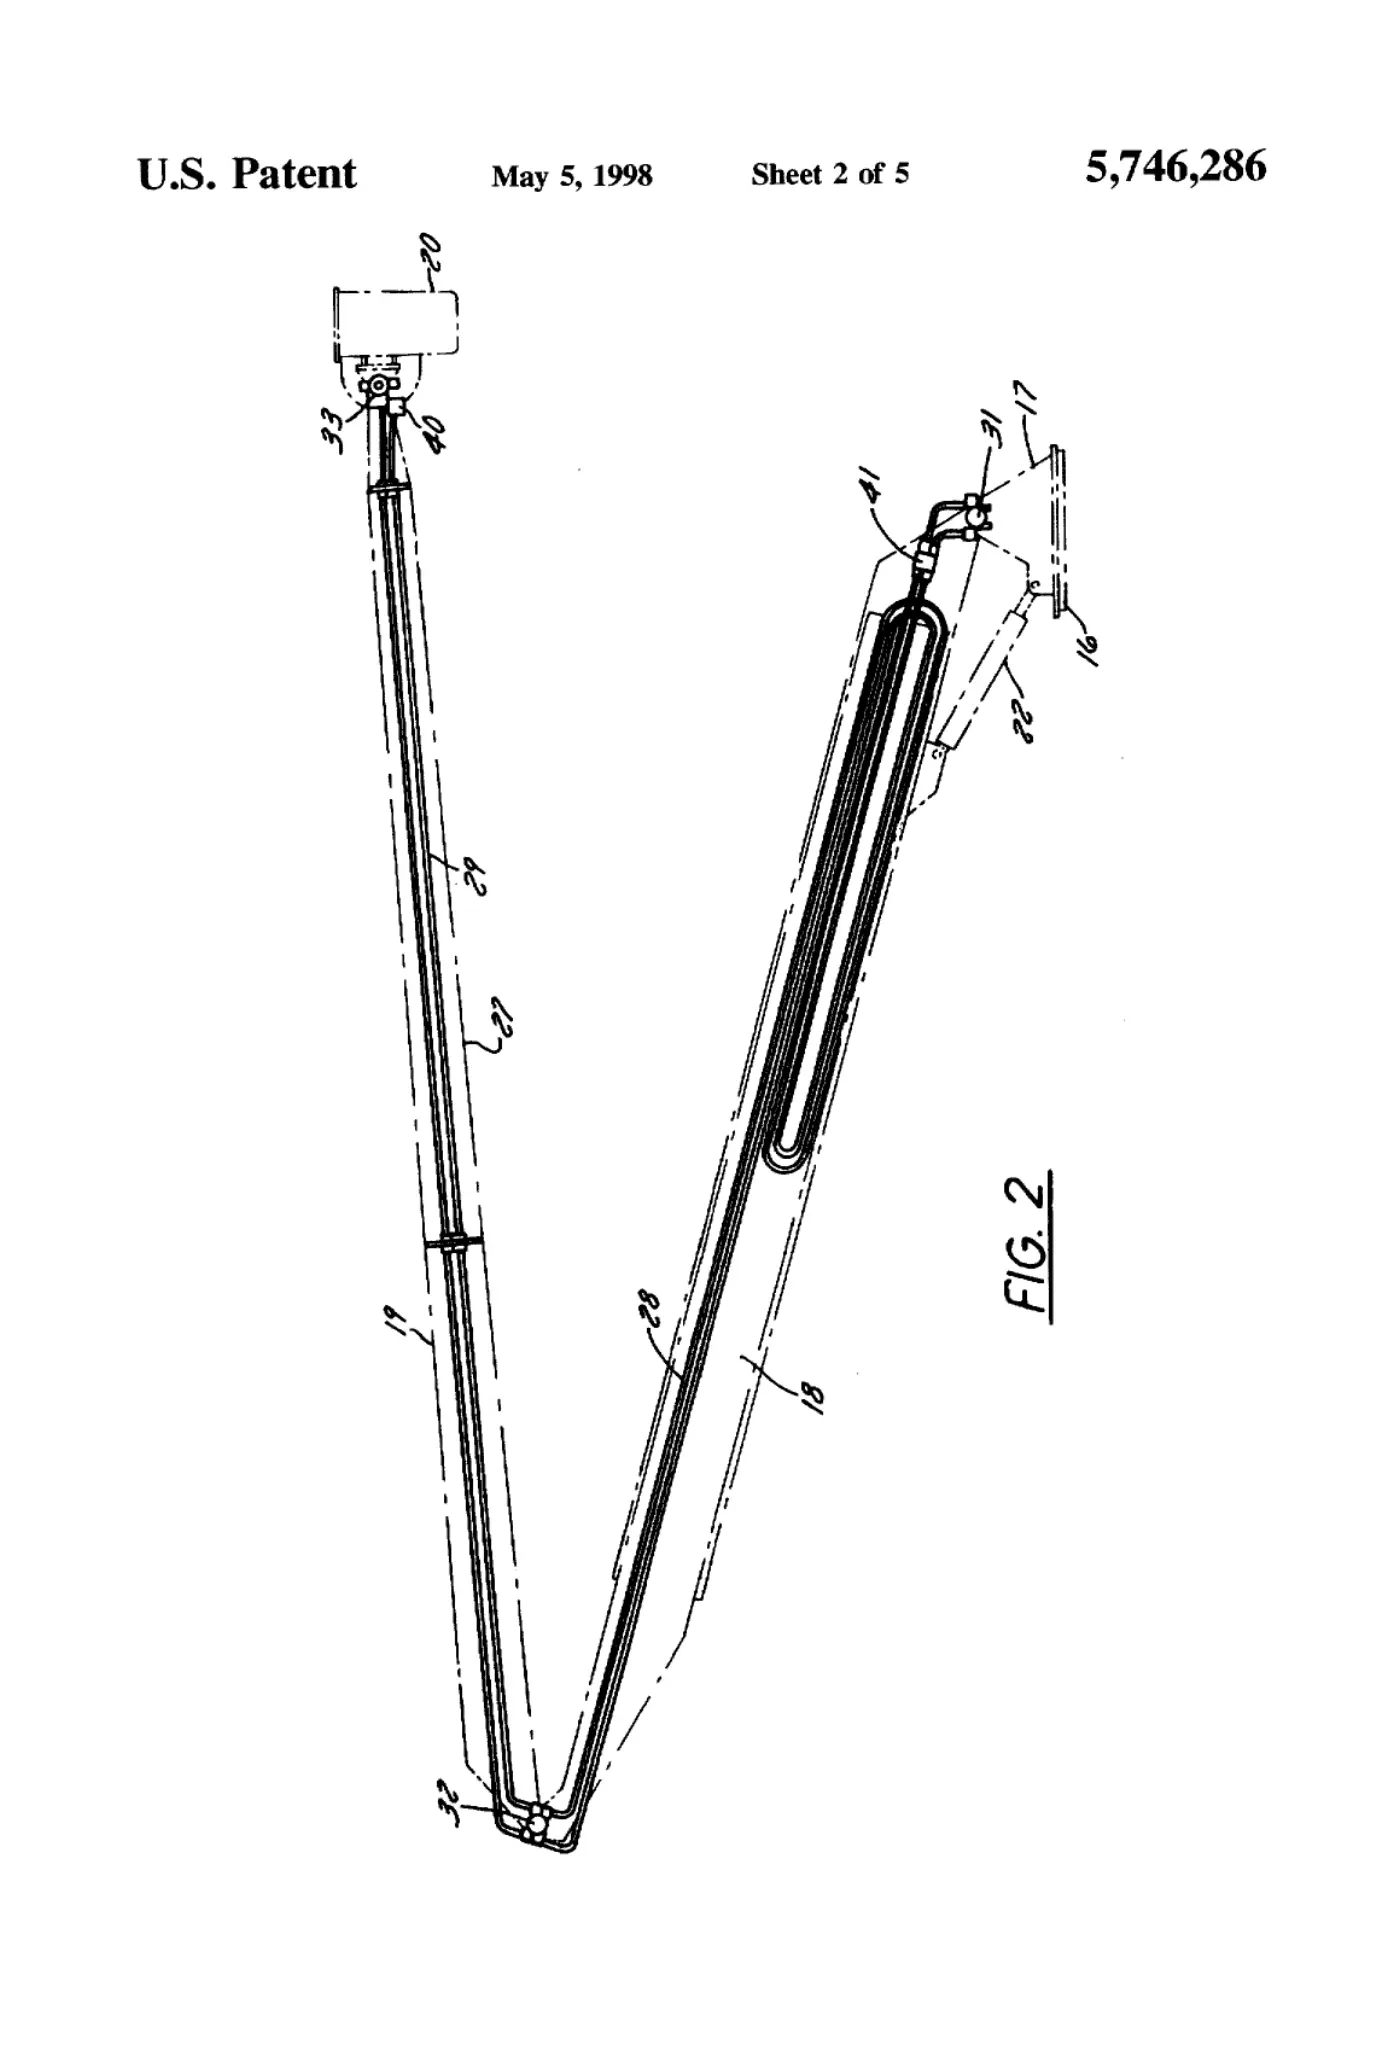
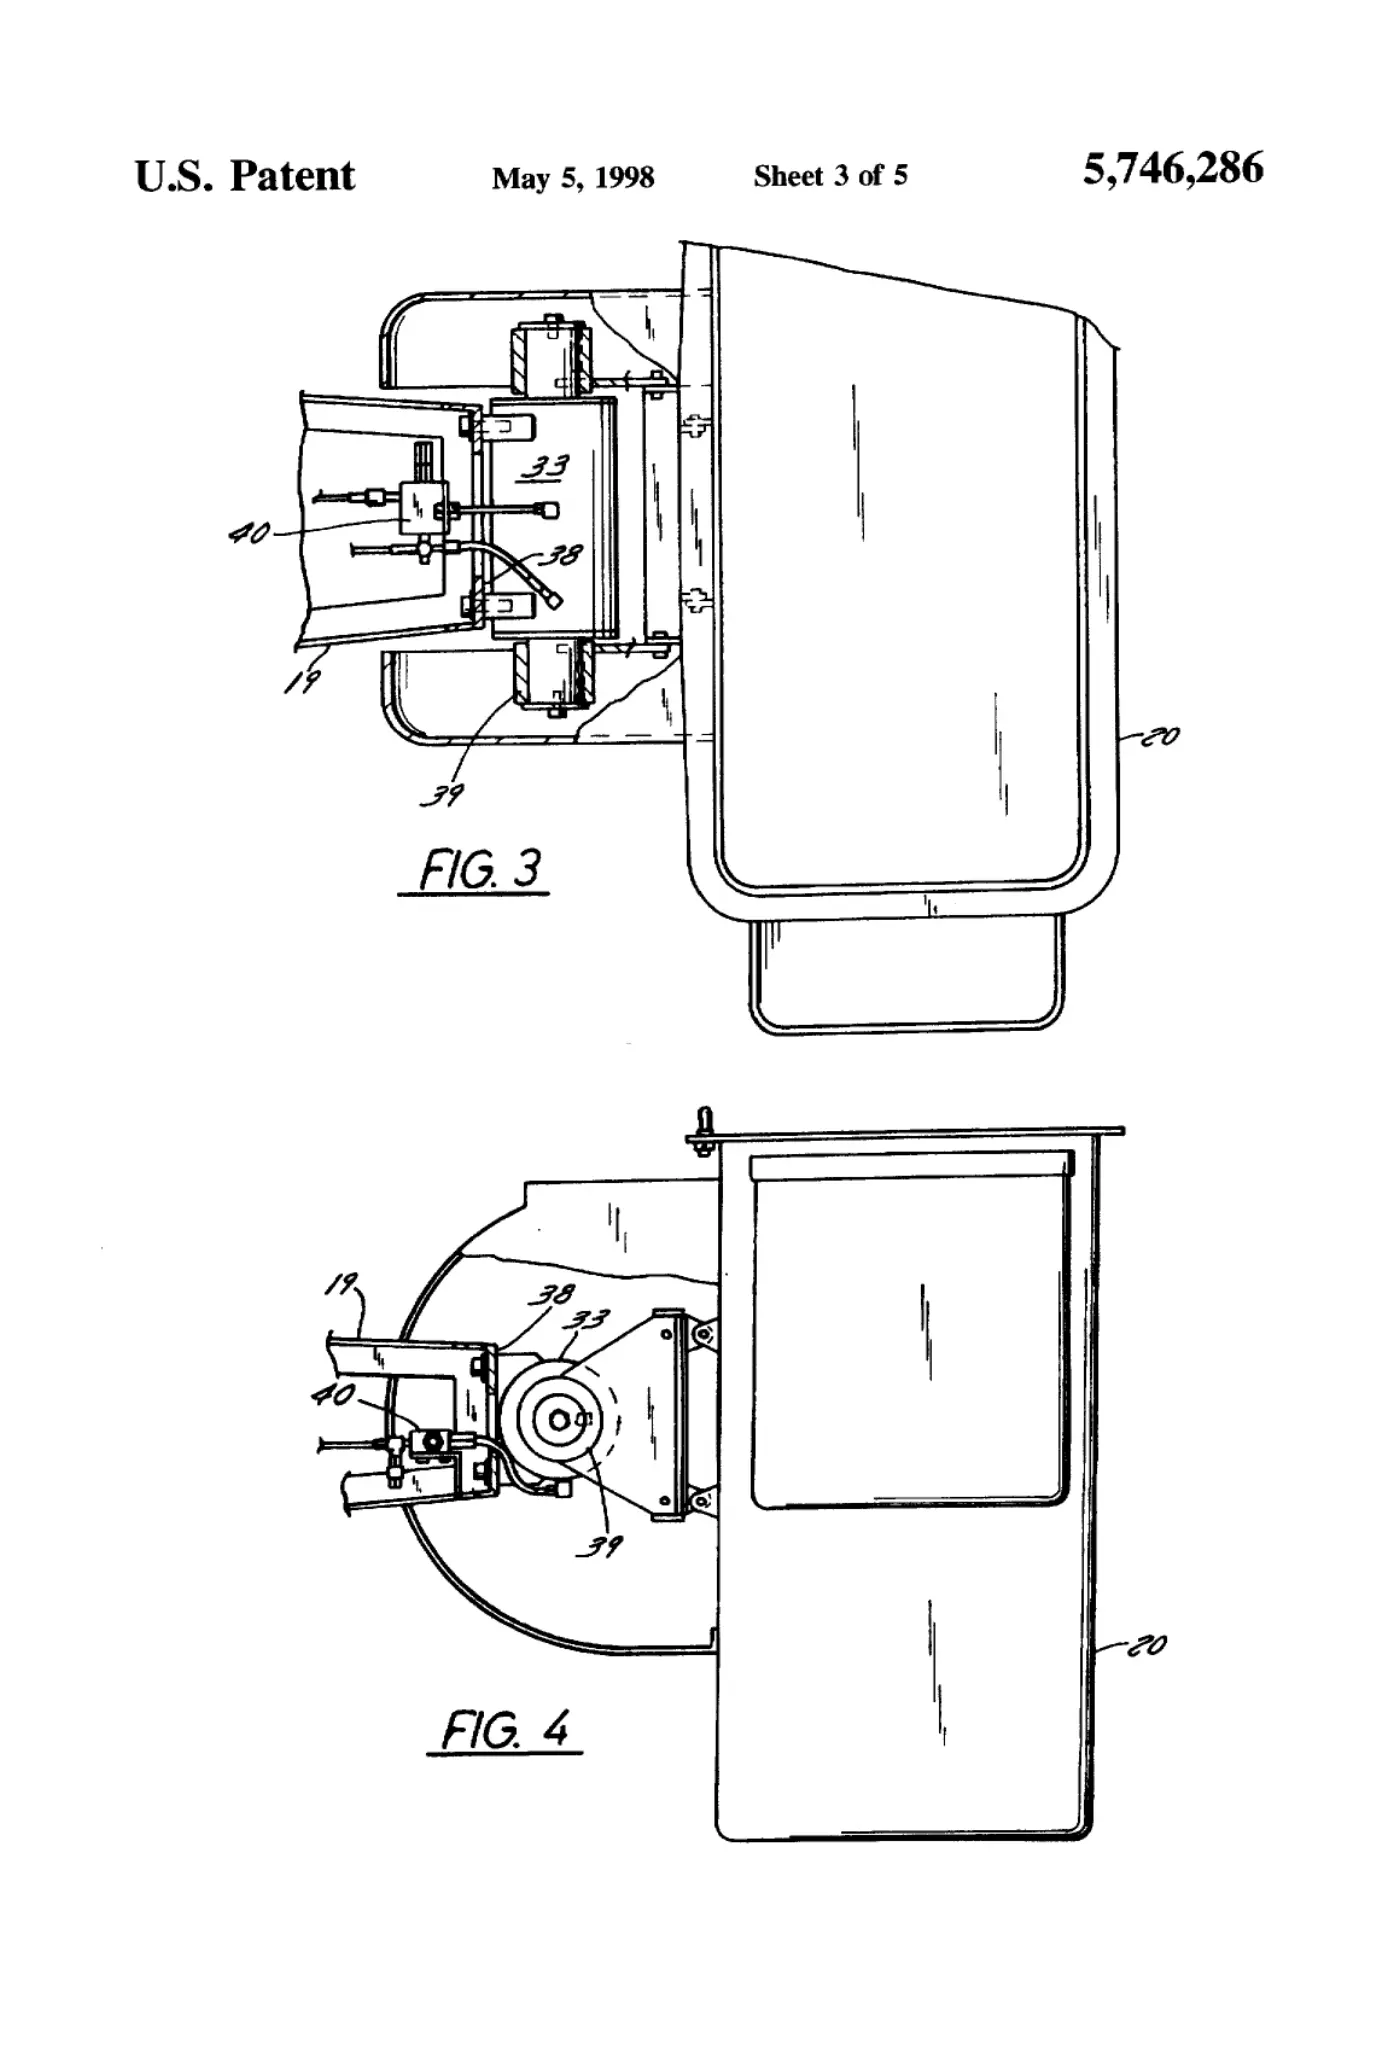
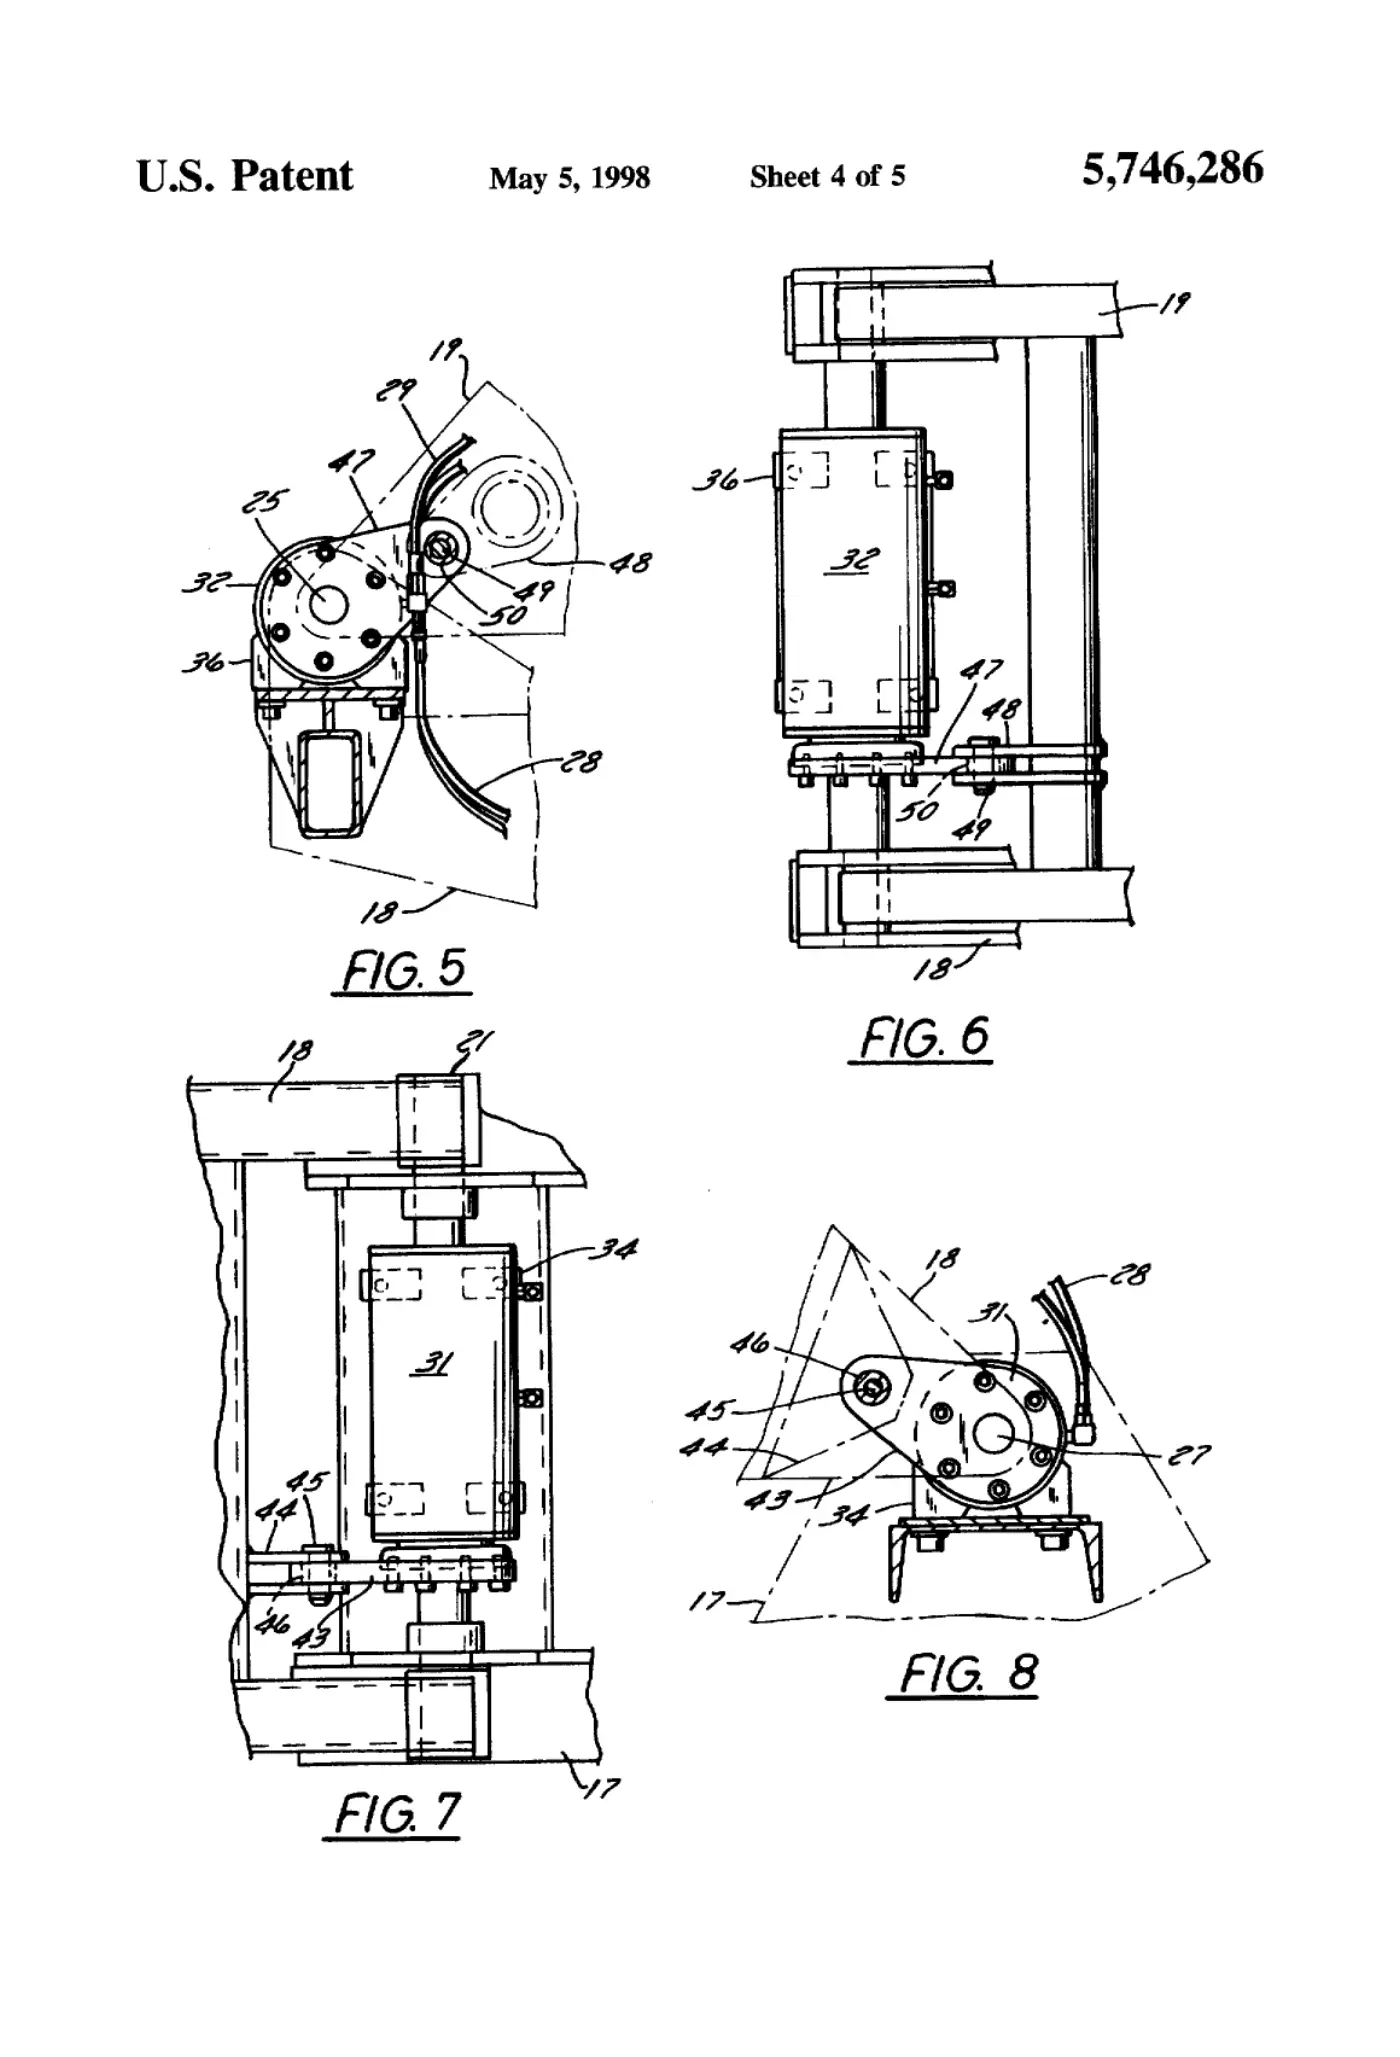
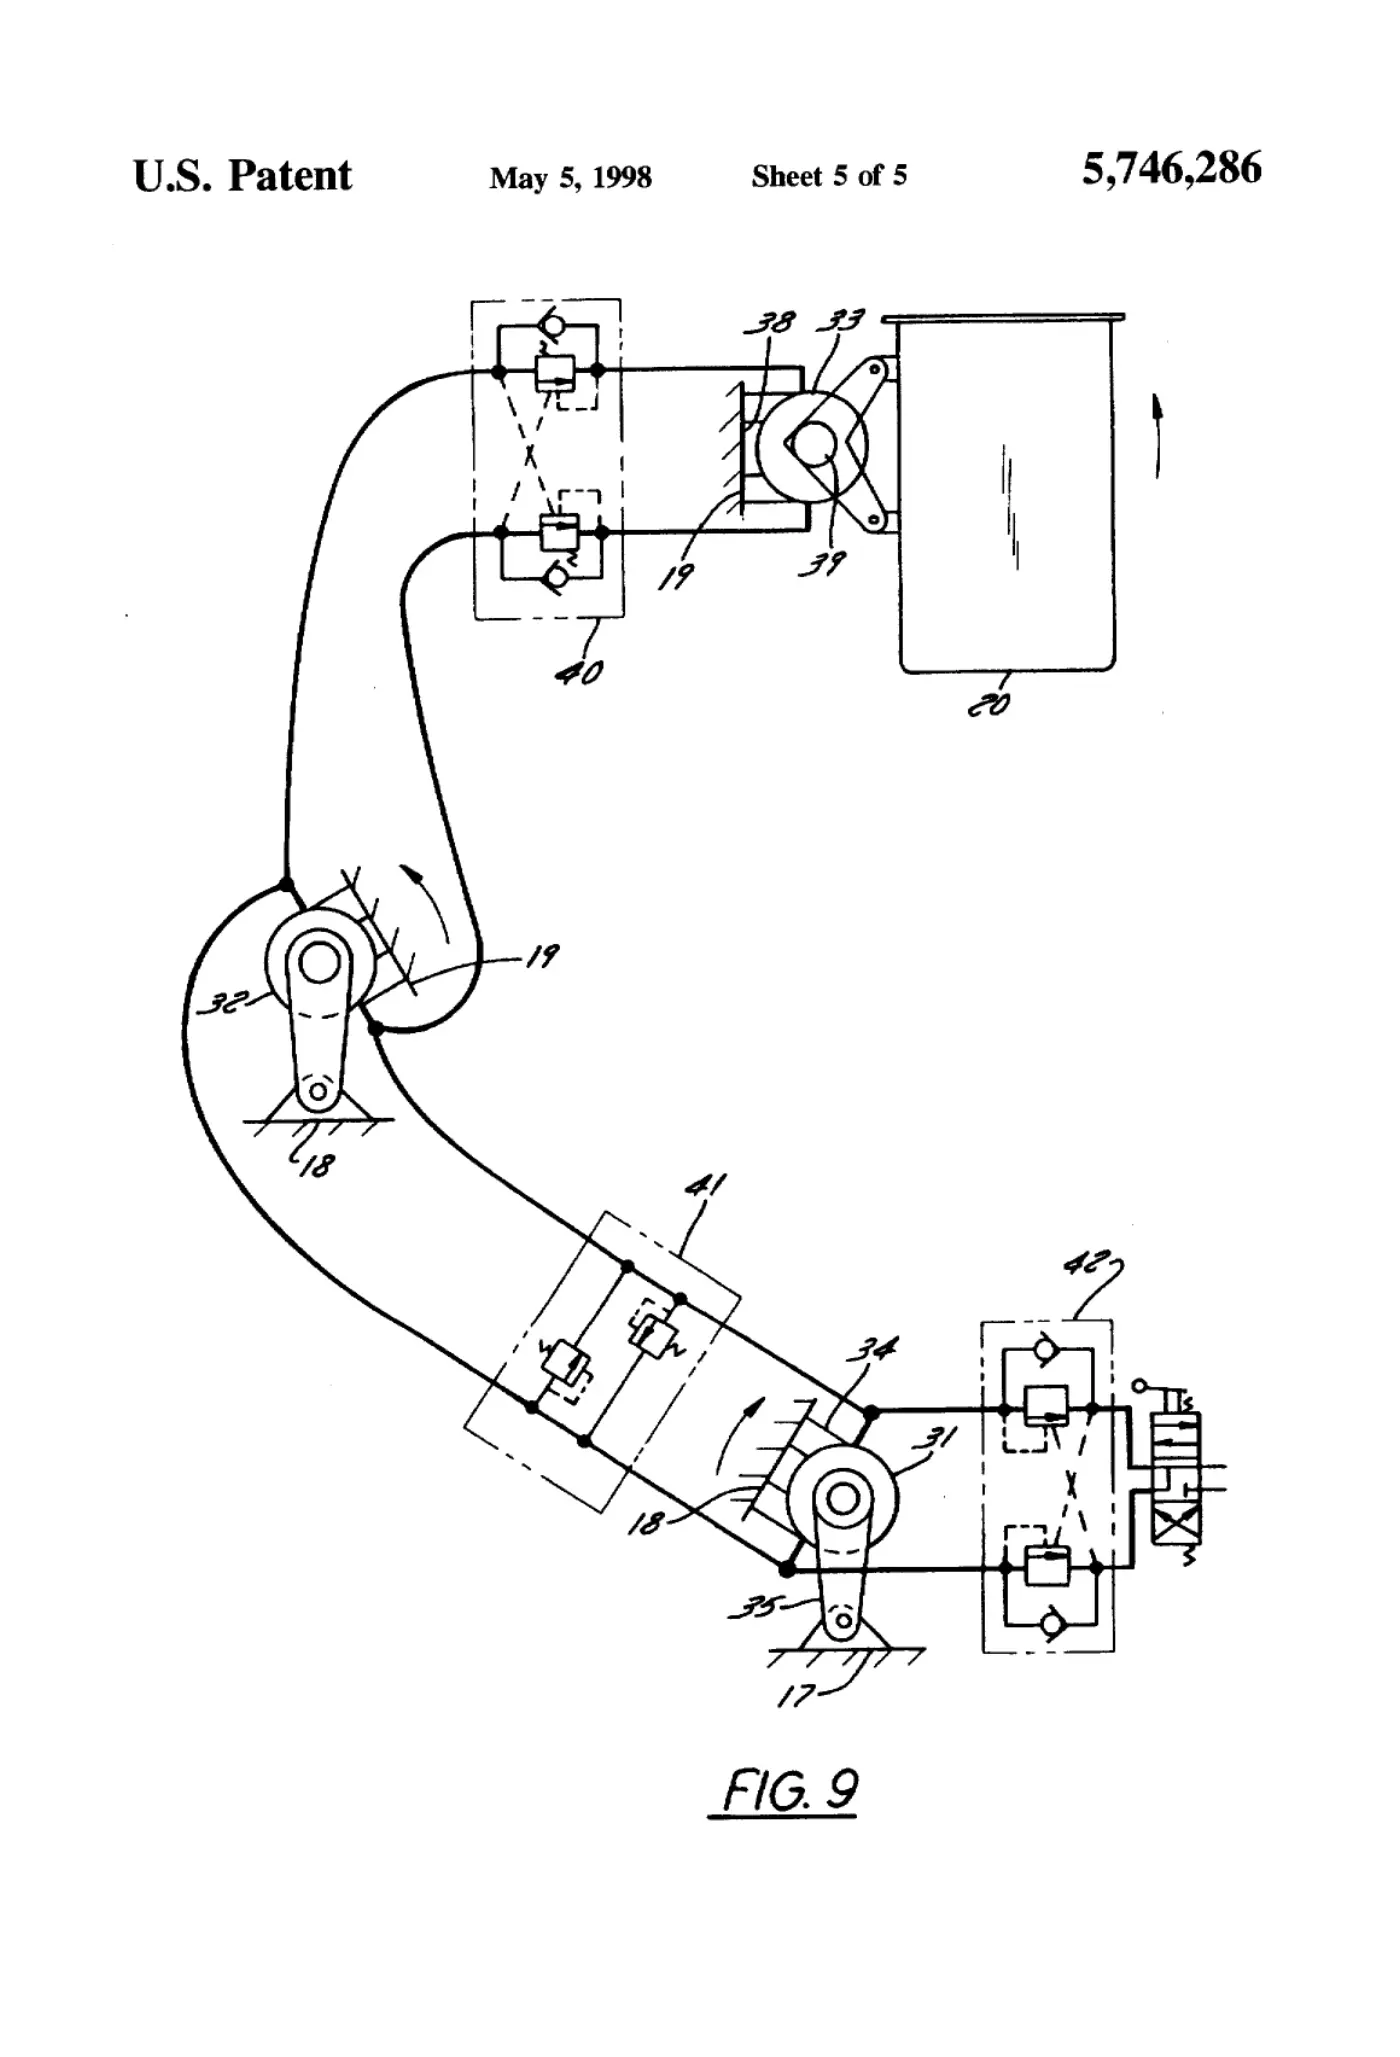
A platform leveling system for an aerial lift truck utilizes a master/slave combination of helical hydraulic rotary actuators to automatically level the work platform in response to movements of the boom. For a two-stage aerial lift comprised of a lower boom and an upper boom, a first rotary actuator is coupled to the base of the lower boom, a second rotary actuator is coupled to the elbow where the upper boom is hinged to the lower boom, and a third rotary actuator is coupled directly to the platform and upper boom. Movement of the lower boom relative to the base causes the first rotary actuator to displace a fixed amount of hydraulic fluid, and movement of the upper boom relative to the lower boom caused the second rotary actuator to disperse a fixed amount of hydraulic fluid. The displacement of hydraulic fluid in the first and second rotary actuators (the master units) causes an equal amount of displacement in the third rotary actuator (the slave unit), which results in articulating the platform in direct response to movement of the boom in order to maintain the platform in a level position.
Abstract
A platform leveling system for an aerial lift truck utilizes a master/slave combination of helical hydraulic rotary actuators to automatically level the work platform in response to movements of the boom. For a two-stage aerial lift comprised of a lower boom and an upper boom, a first rotary actuator is coupled to the base of the lower boom, a second rotary actuator is coupled to the elbow where the upper boom is hinged to the lower boom, and a third rotary actuator is coupled directly to the platform and upper boom. Movement of the lower boom relative to the base causes the first rotary actuator to displace a fixed amount of hydraulic fluid, and movement of the upper boom relative to the lower boom caused the second rotary actuator to disperse a fixed amount of hydraulic fluid. The displacement of hydraulic fluid in the first and second rotary actuators (the master units) causes an equal amount of displacement in the third rotary actuator (the slave unit), which results in articulating the platform in direct response to movement of the boom in order to maintain the platform in a level position.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
[0005]Sheet 5.
Publication information
Citation
OpenTechnical Publication OT-2026-000003217, “Hydraulic boom platform leveling system,” published September 15, 2026 at 19:51:15 UTC, https://opentechnical.org/p/OT-2026-000003217.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.