OT-2026-000003242
Robots using modular direct drive motors
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003242
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- HANSEN FREDERICK B, WALLACE RICHARD S
- Assignee
- UNIV NEW YORK
- Original source
- US-5672924-A, the United States Patent and Trademark Office, 30 September 1997
- Document SHA-256
- a225cd09898a3bbc0213c7b2fc90fa6389009a6ae16cf99130ace00c121591b1
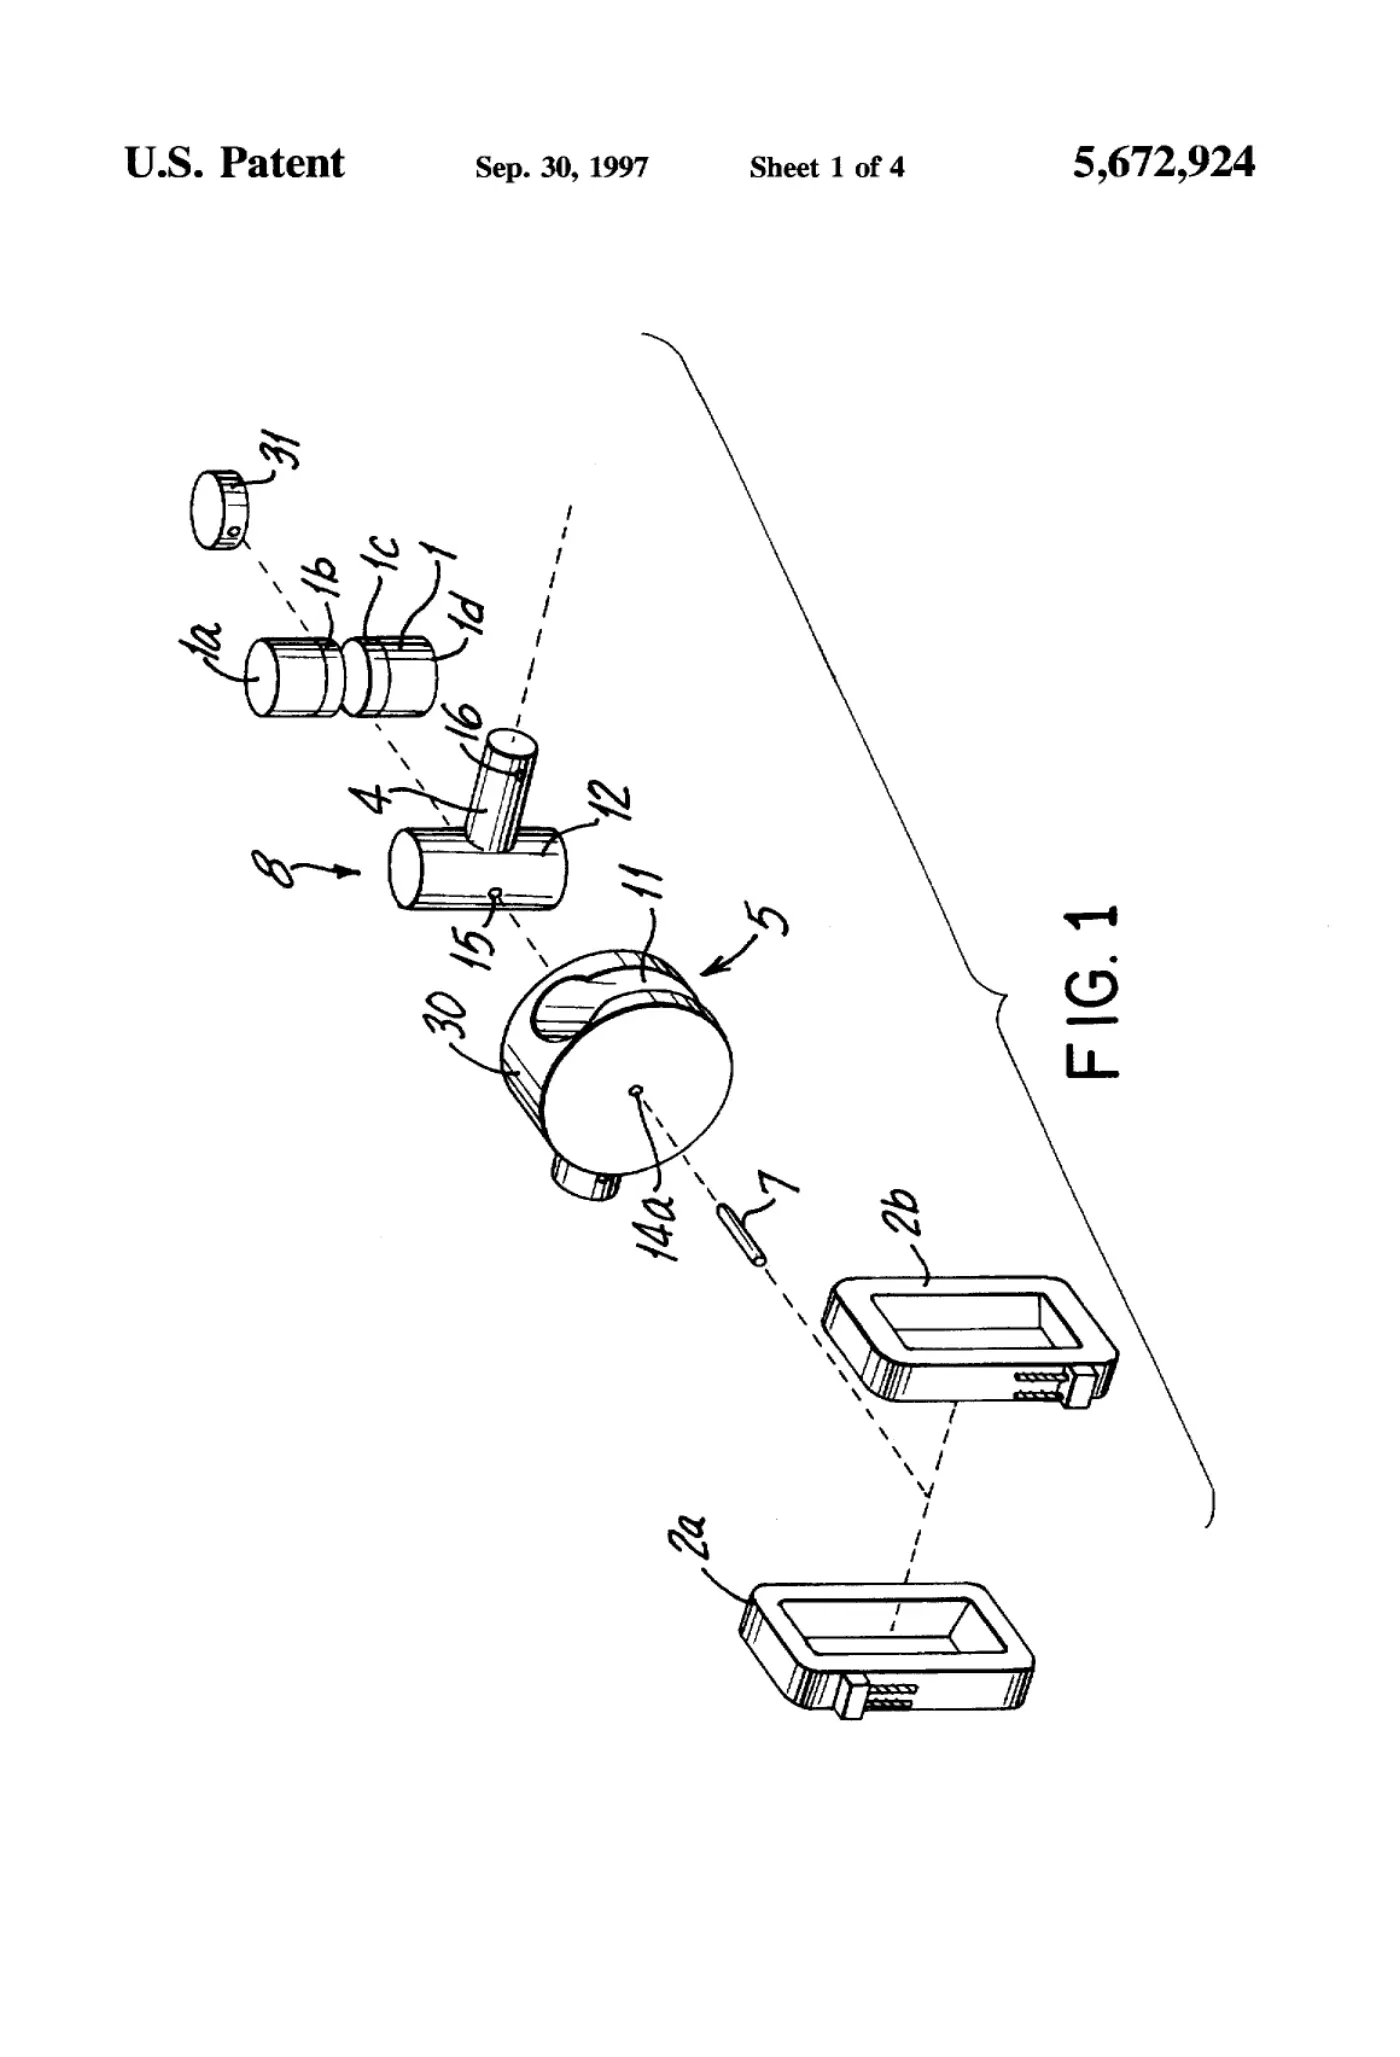
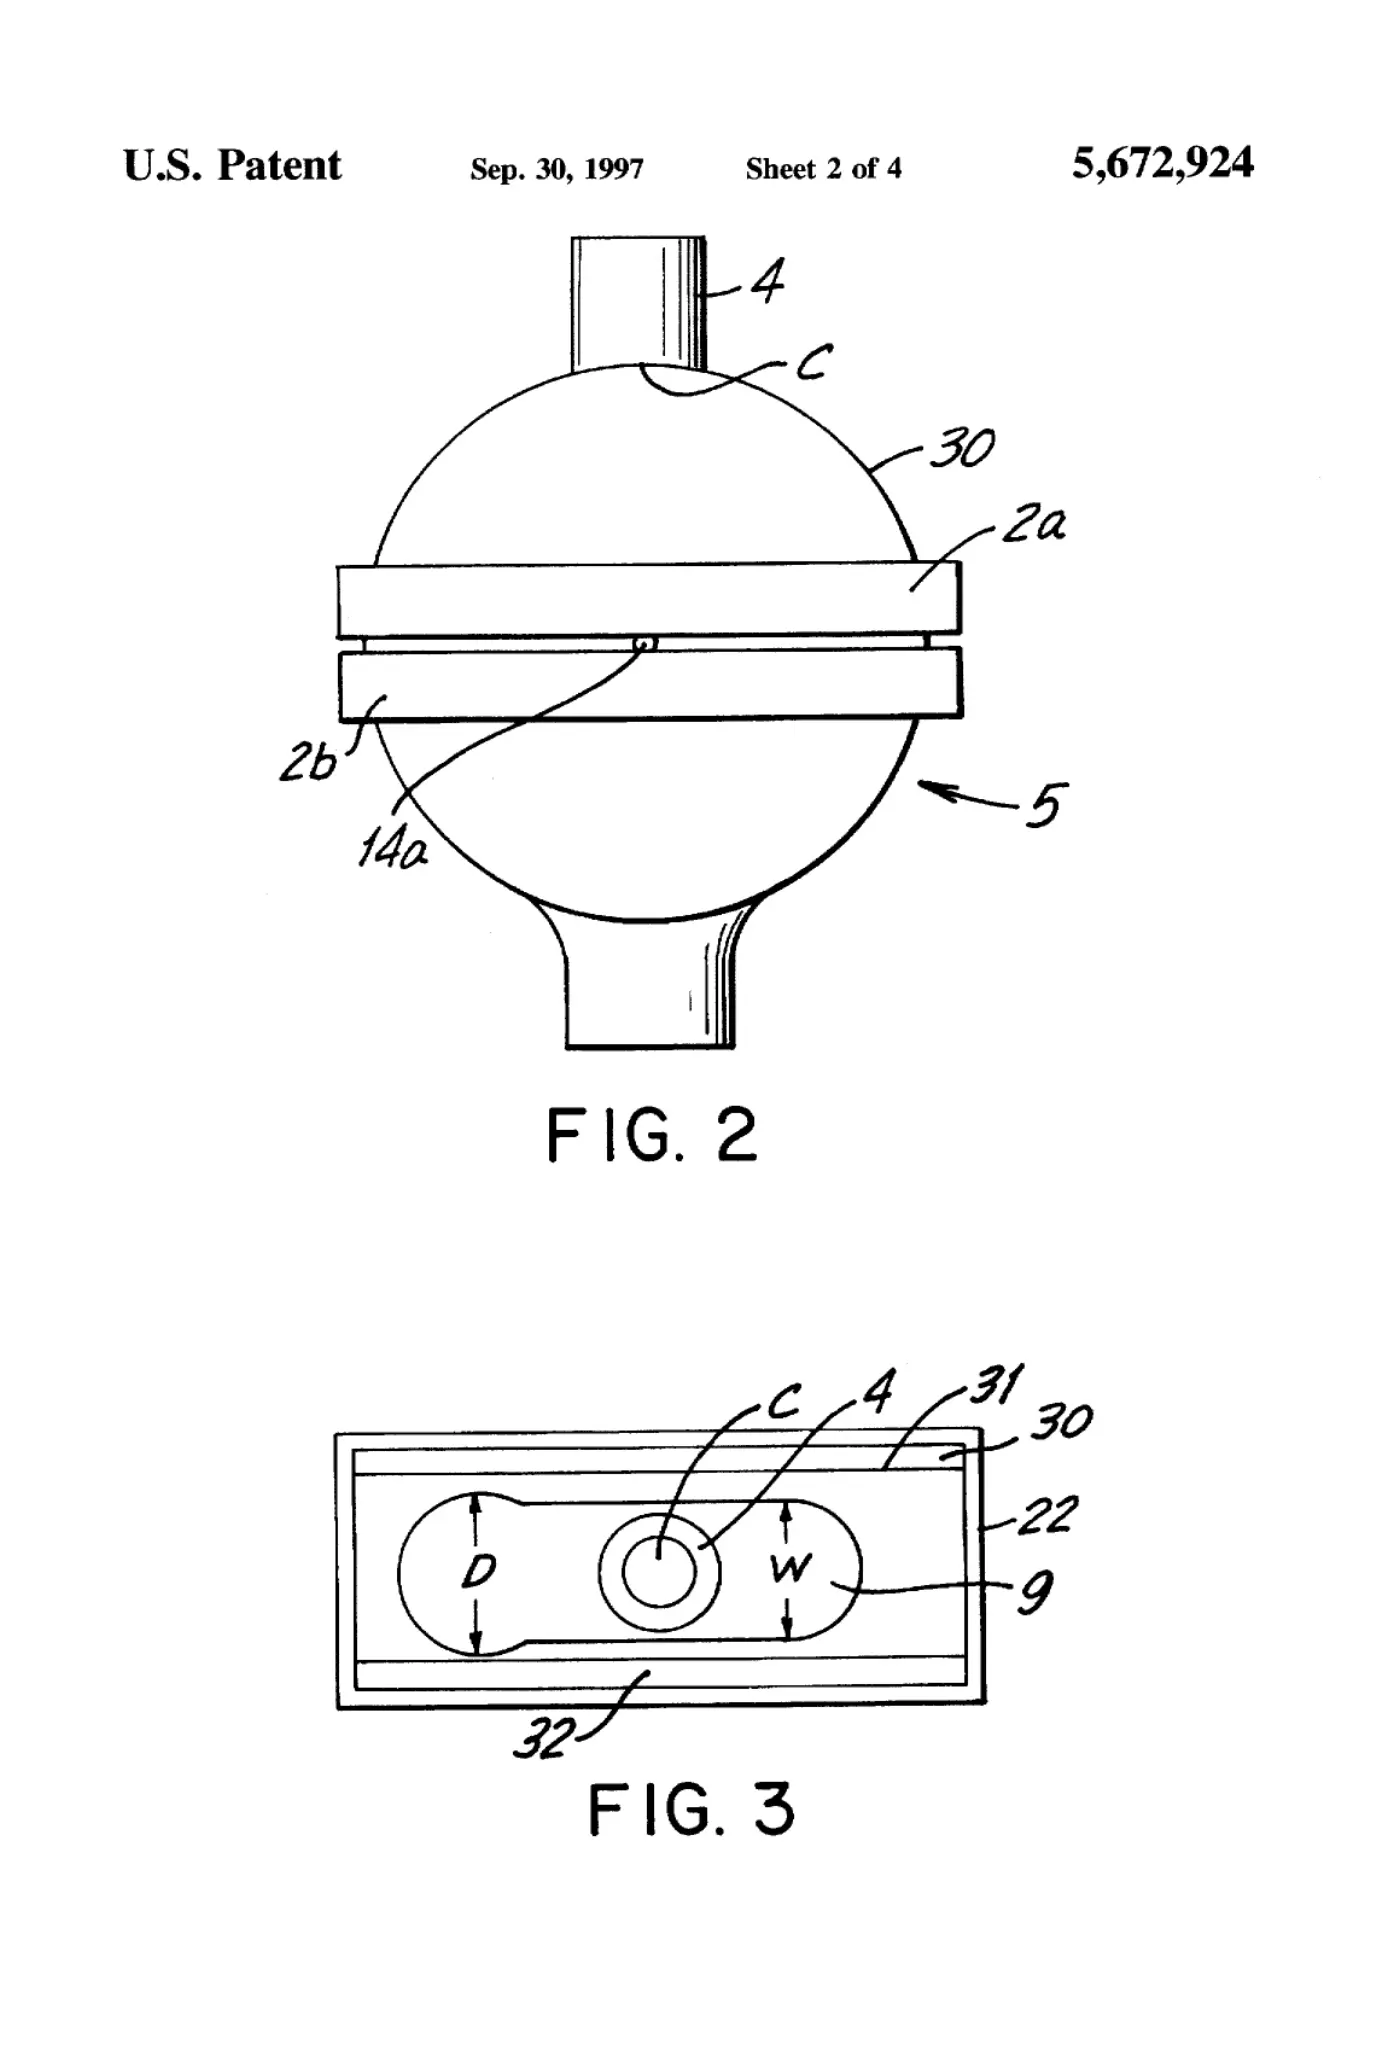
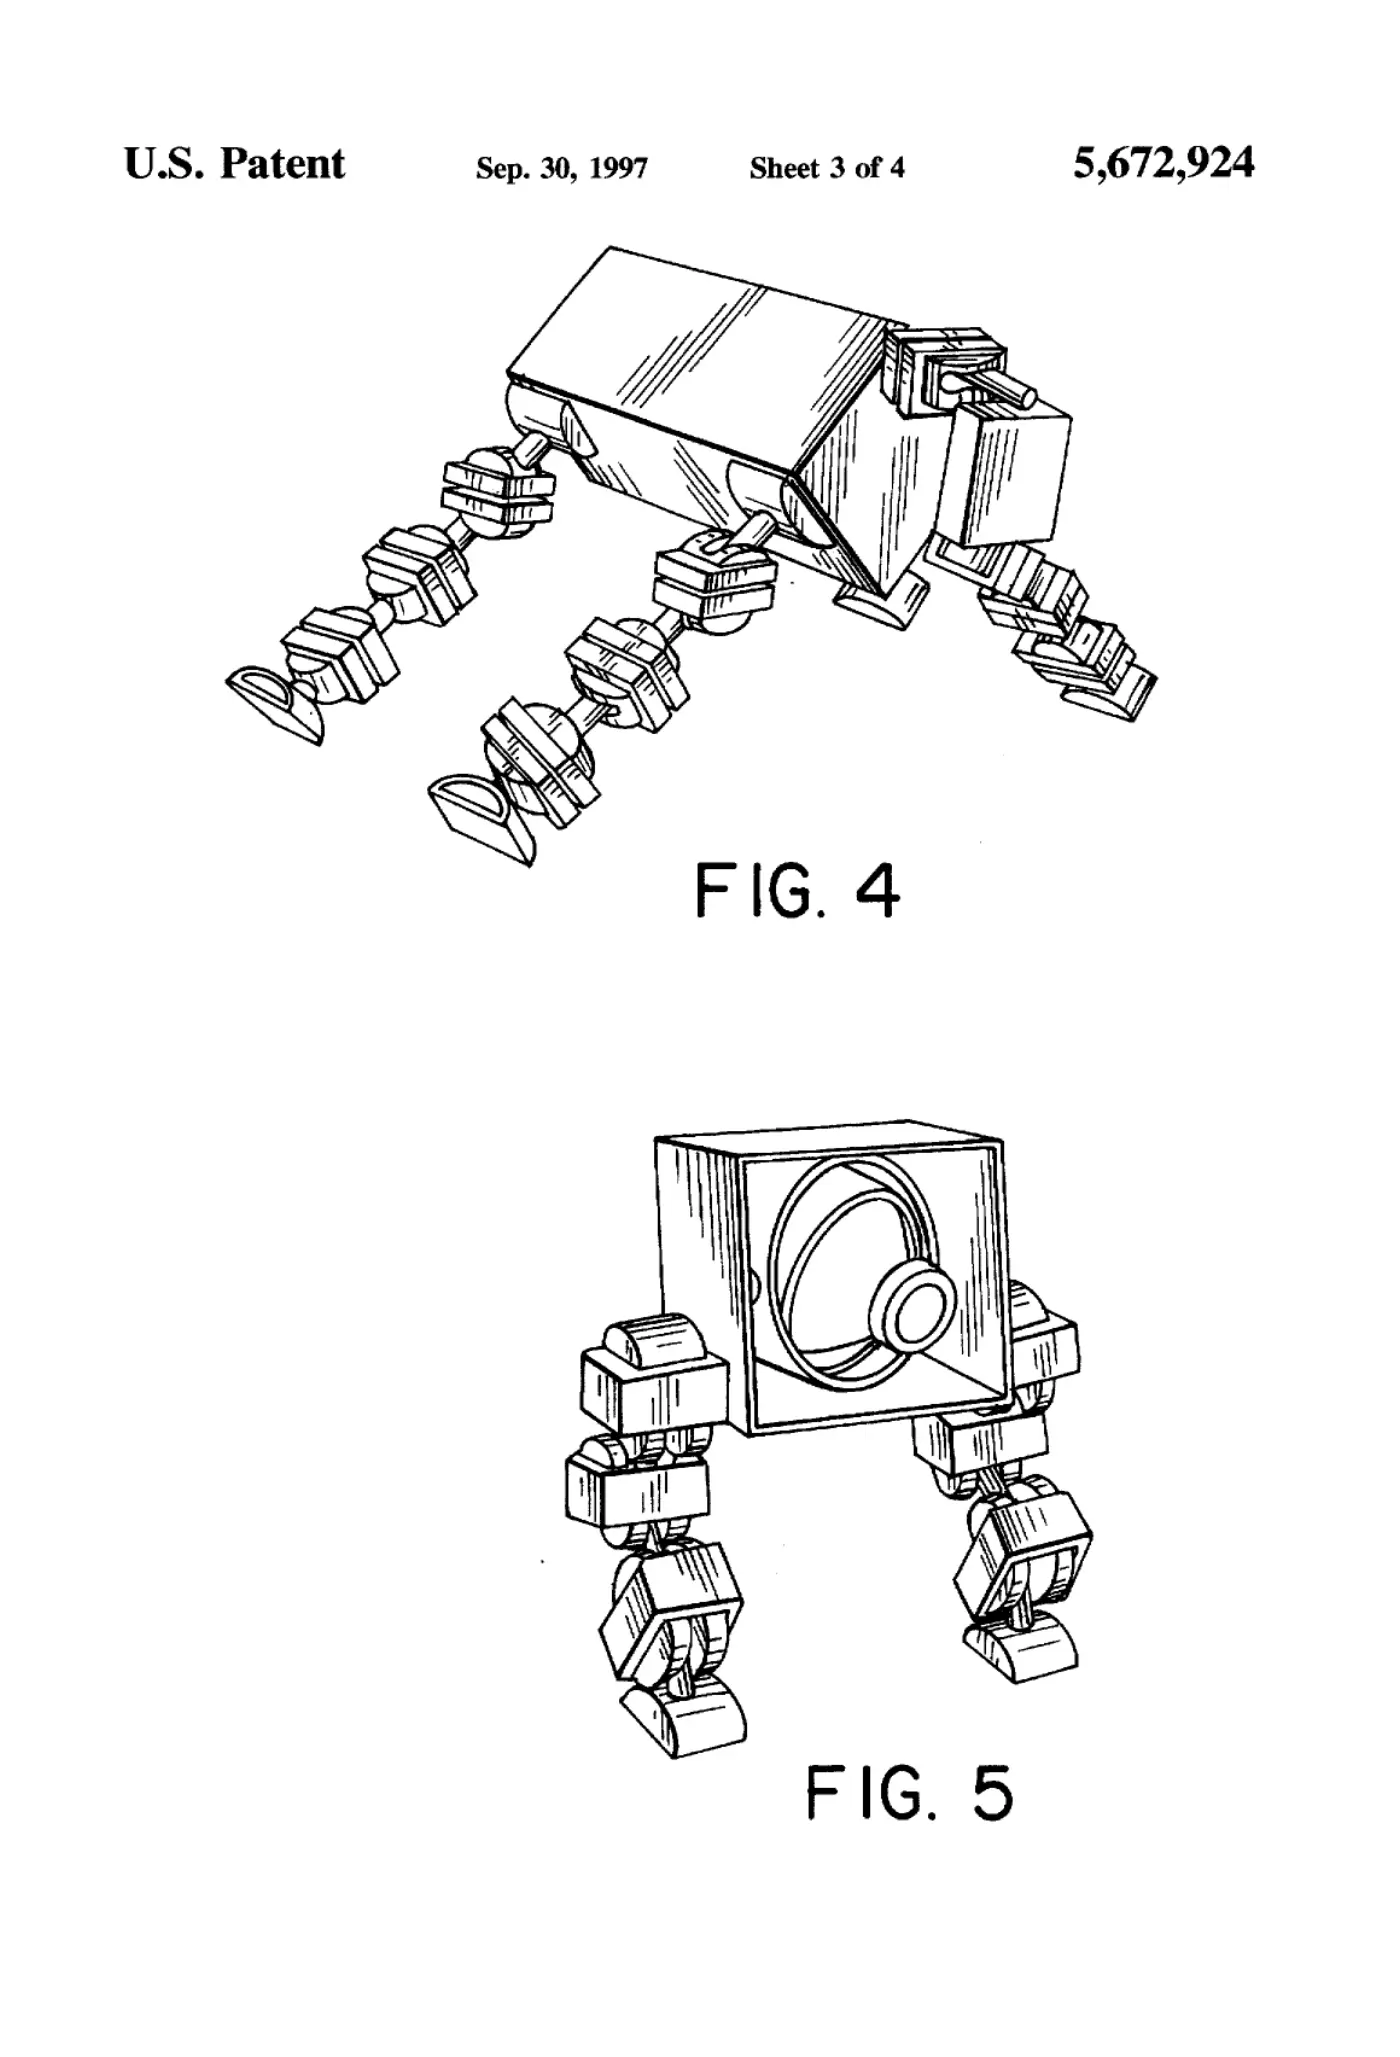
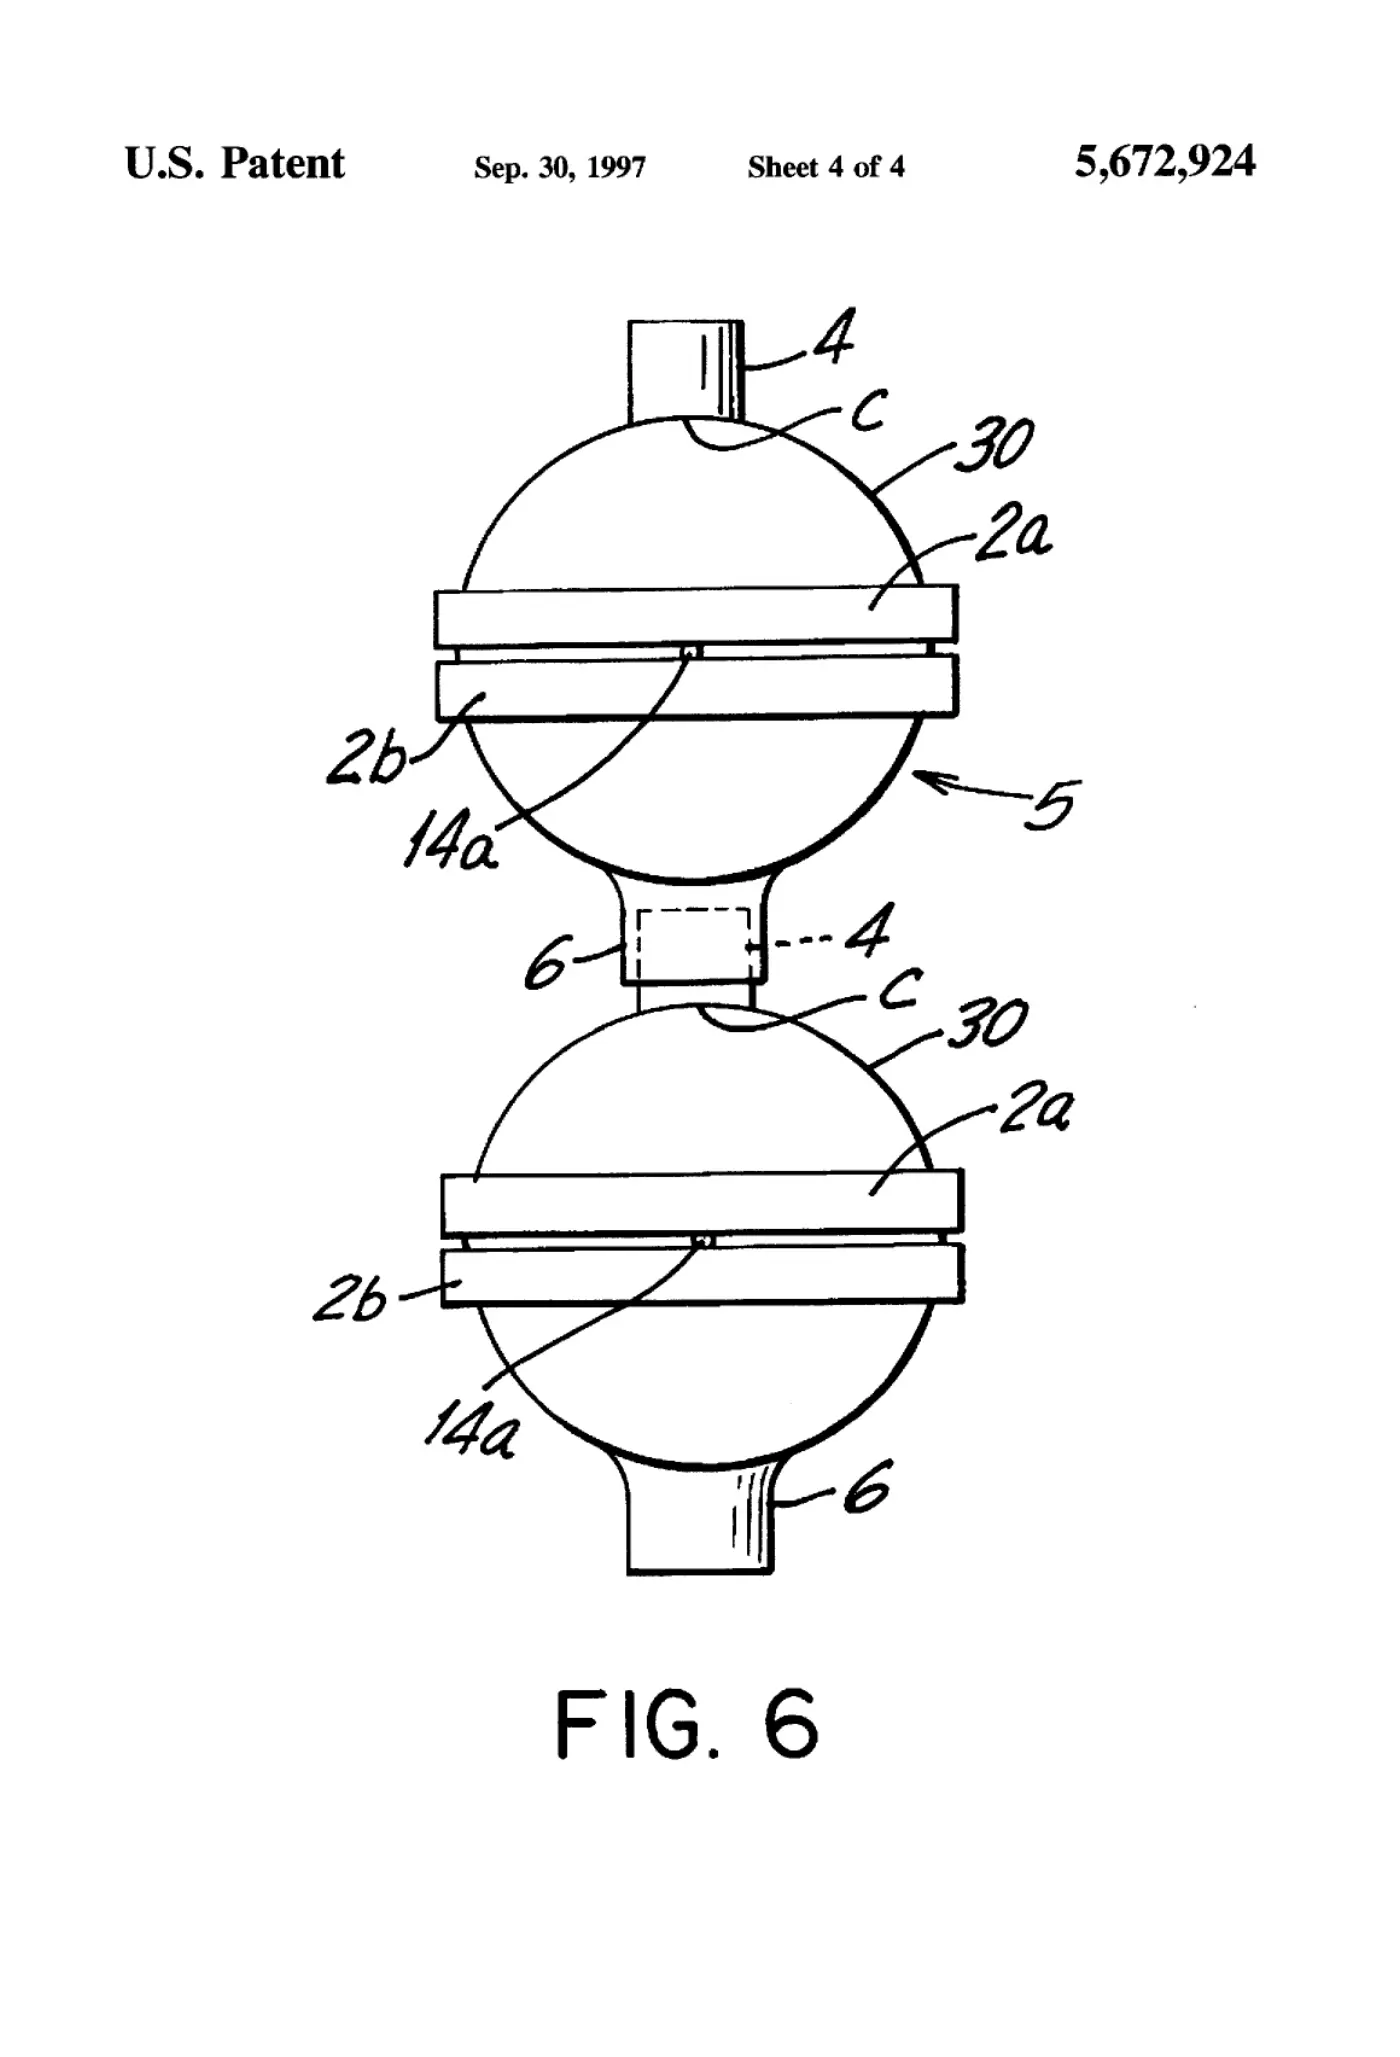
A direct drive robot motor may be used for the arms, legs, eyes and fingers of a robot. The motor comprises a rotor, having a permanent magnet, and a tubular arm portion, which is integral with the rotor and extends outwardly through a slot in a stator body. The stator body is wound with an aluminum coil and has a tubular extension to link it with the arm of another direct drive motor.
Abstract
A direct drive robot motor may be used for the arms, legs, eyes and fingers of a robot. The motor comprises a rotor, having a permanent magnet, and a tubular arm portion, which is integral with the rotor and extends outwardly through a slot in a stator body. The stator body is wound with an aluminum coil and has a tubular extension to link it with the arm of another direct drive motor.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
[0005]Sheet 5.
Publication information
Citation
OpenTechnical Publication OT-2026-000003242, “Robots using modular direct drive motors,” published September 15, 2026 at 19:55:28 UTC, https://opentechnical.org/p/OT-2026-000003242.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.