OT-2026-000003267
Robot manipulator
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003267
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- FINK FRIEDHELM, FUCHS HANS-WERNER, PANTHEL KLAUS
- Assignee
- HAUNI MASCHINENBAU AG
- Original source
- US-5605432-A, the United States Patent and Trademark Office, 25 February 1997
- Document SHA-256
- 1beb052bd3018e0a6f3c32f5d94e93a03d94b3b48c48b08d99499b1b7c4ba52d
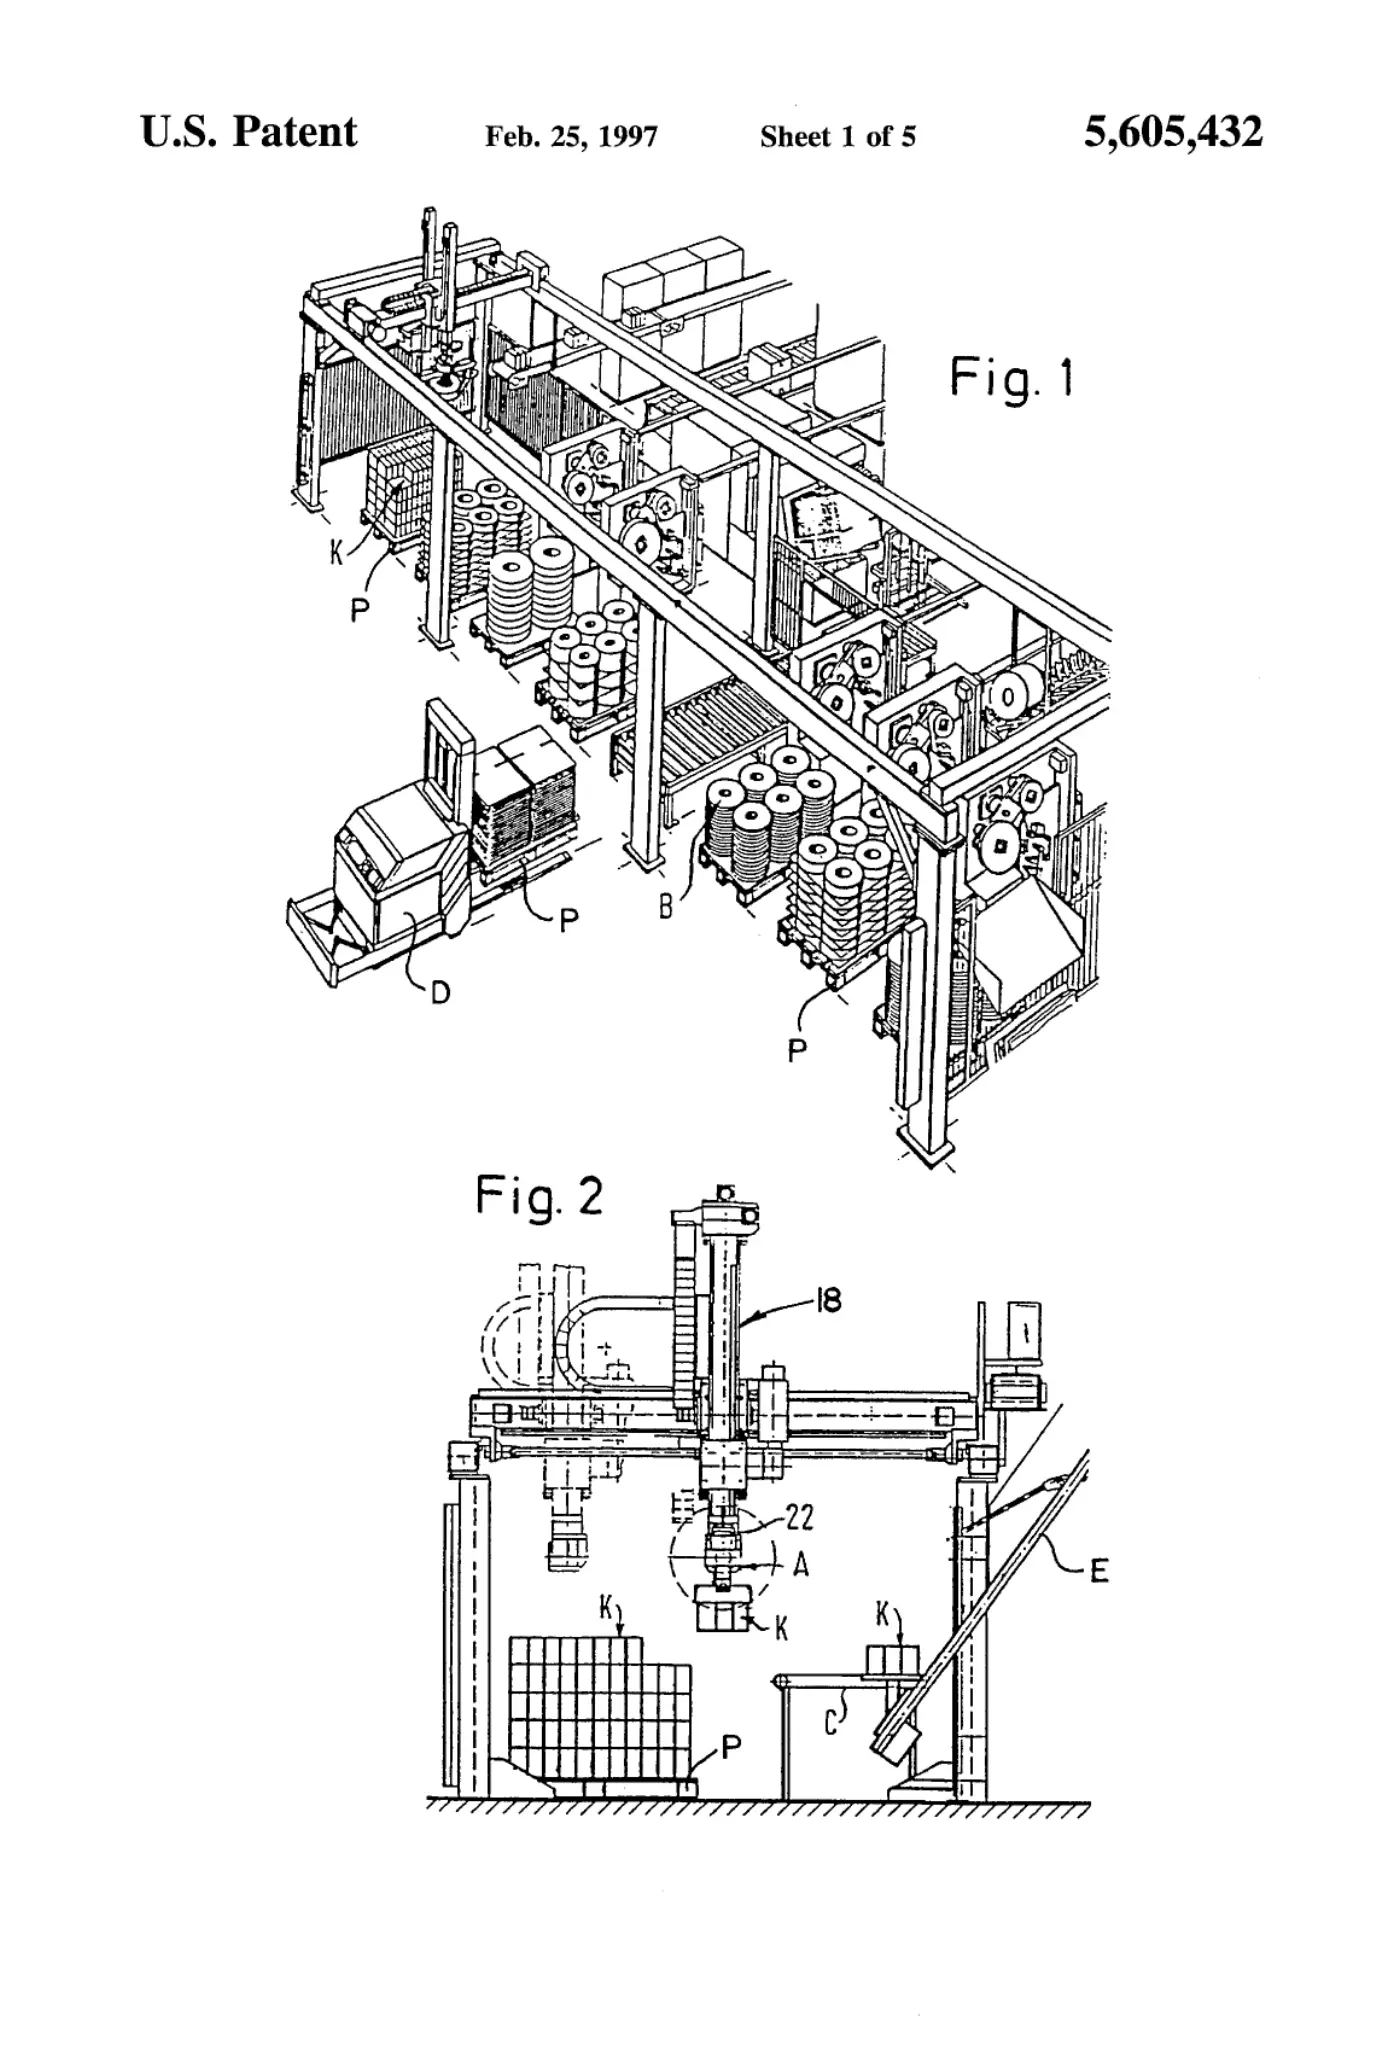
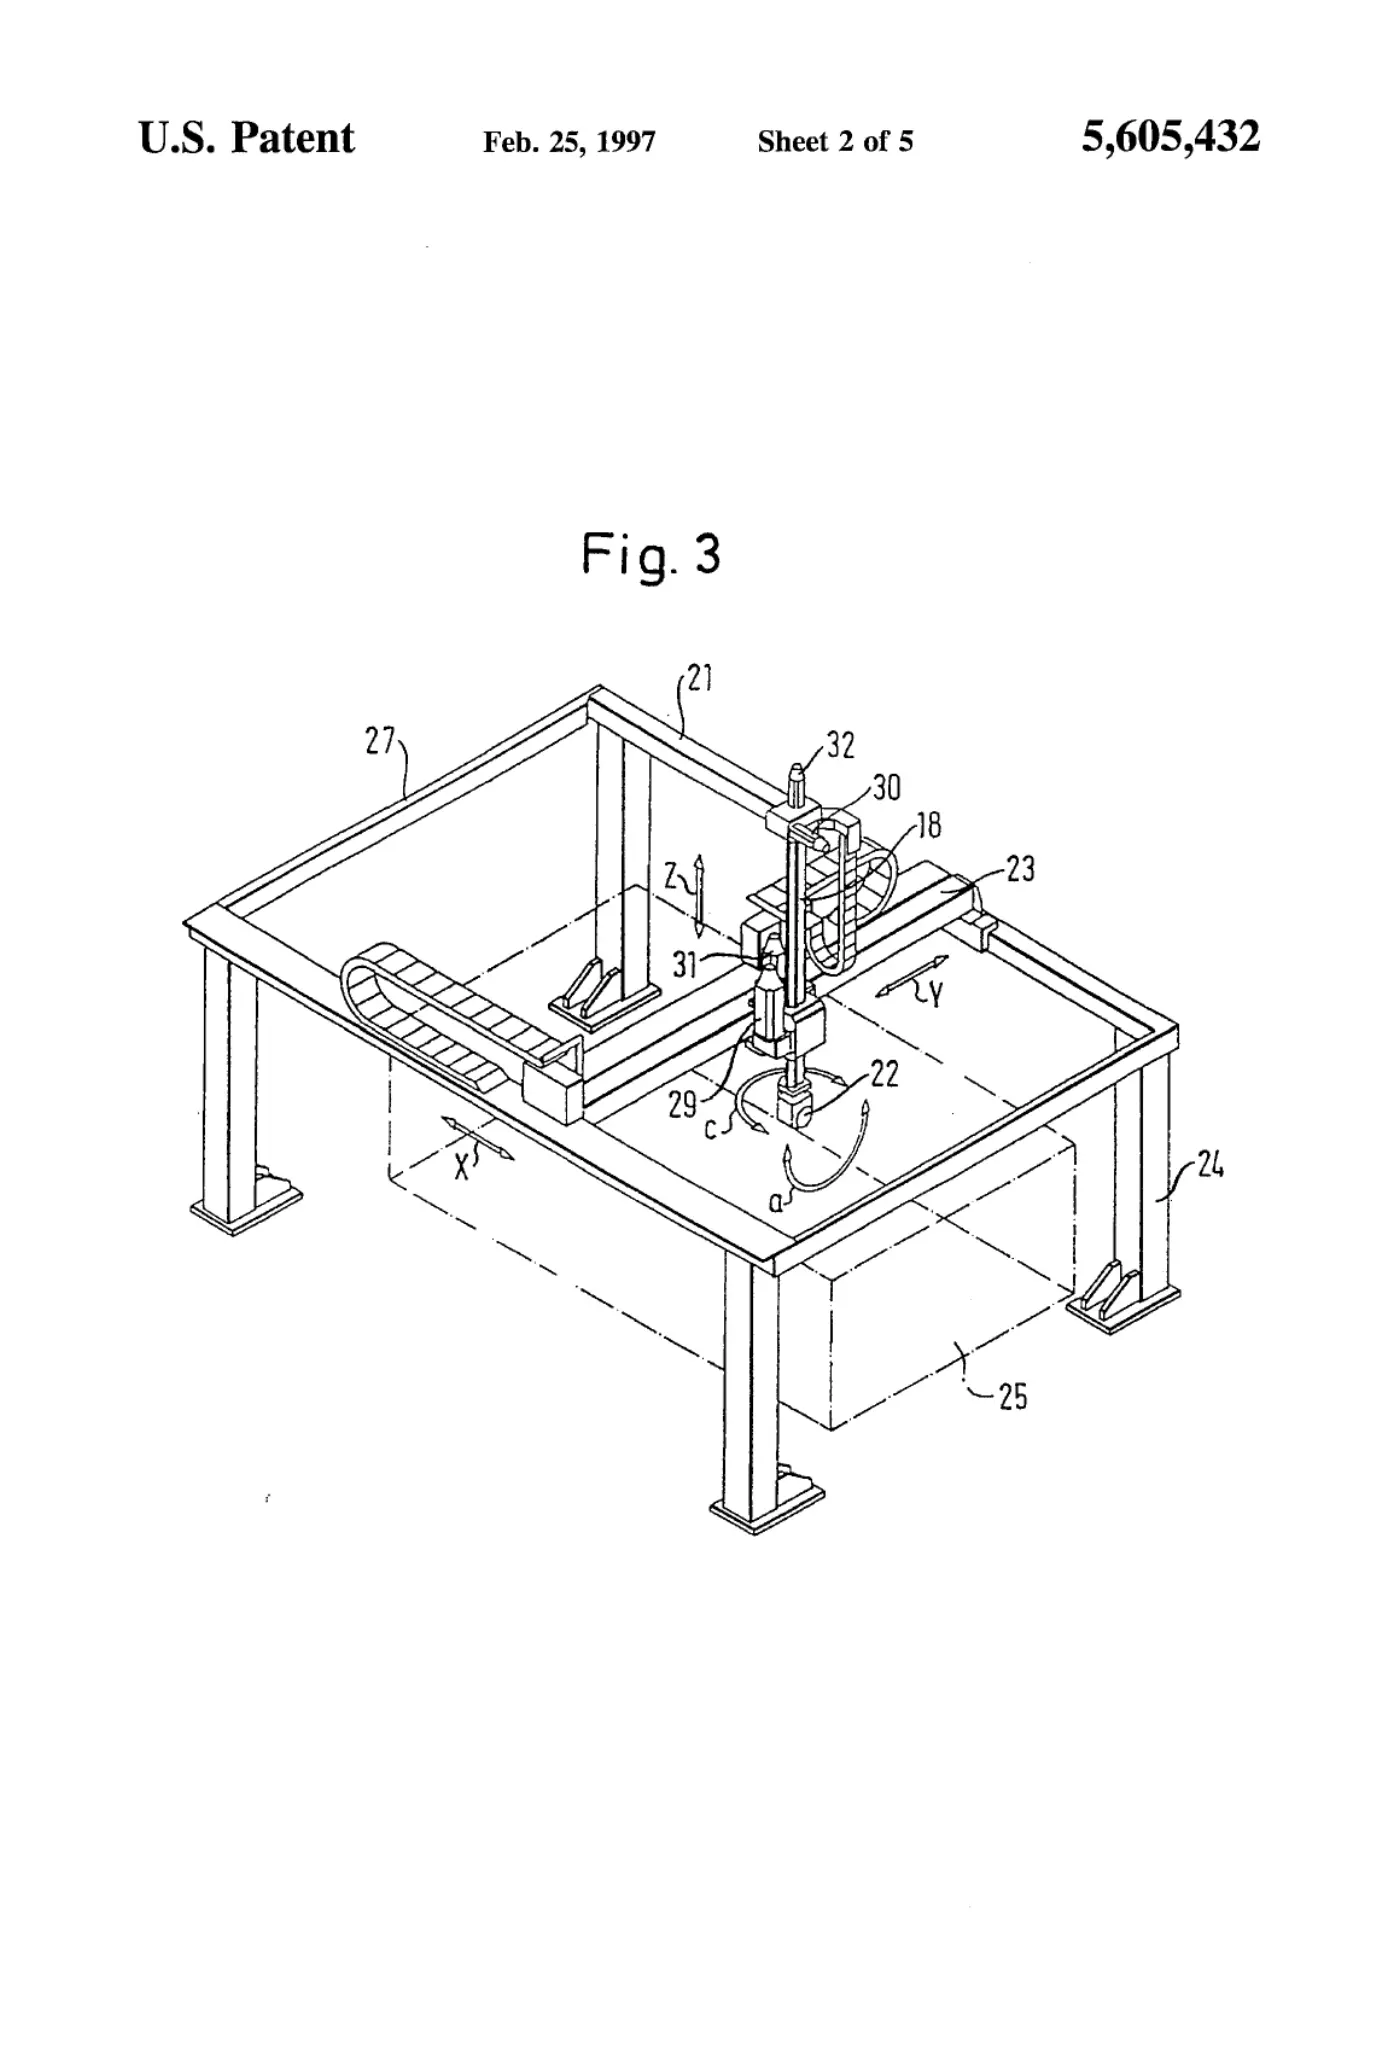
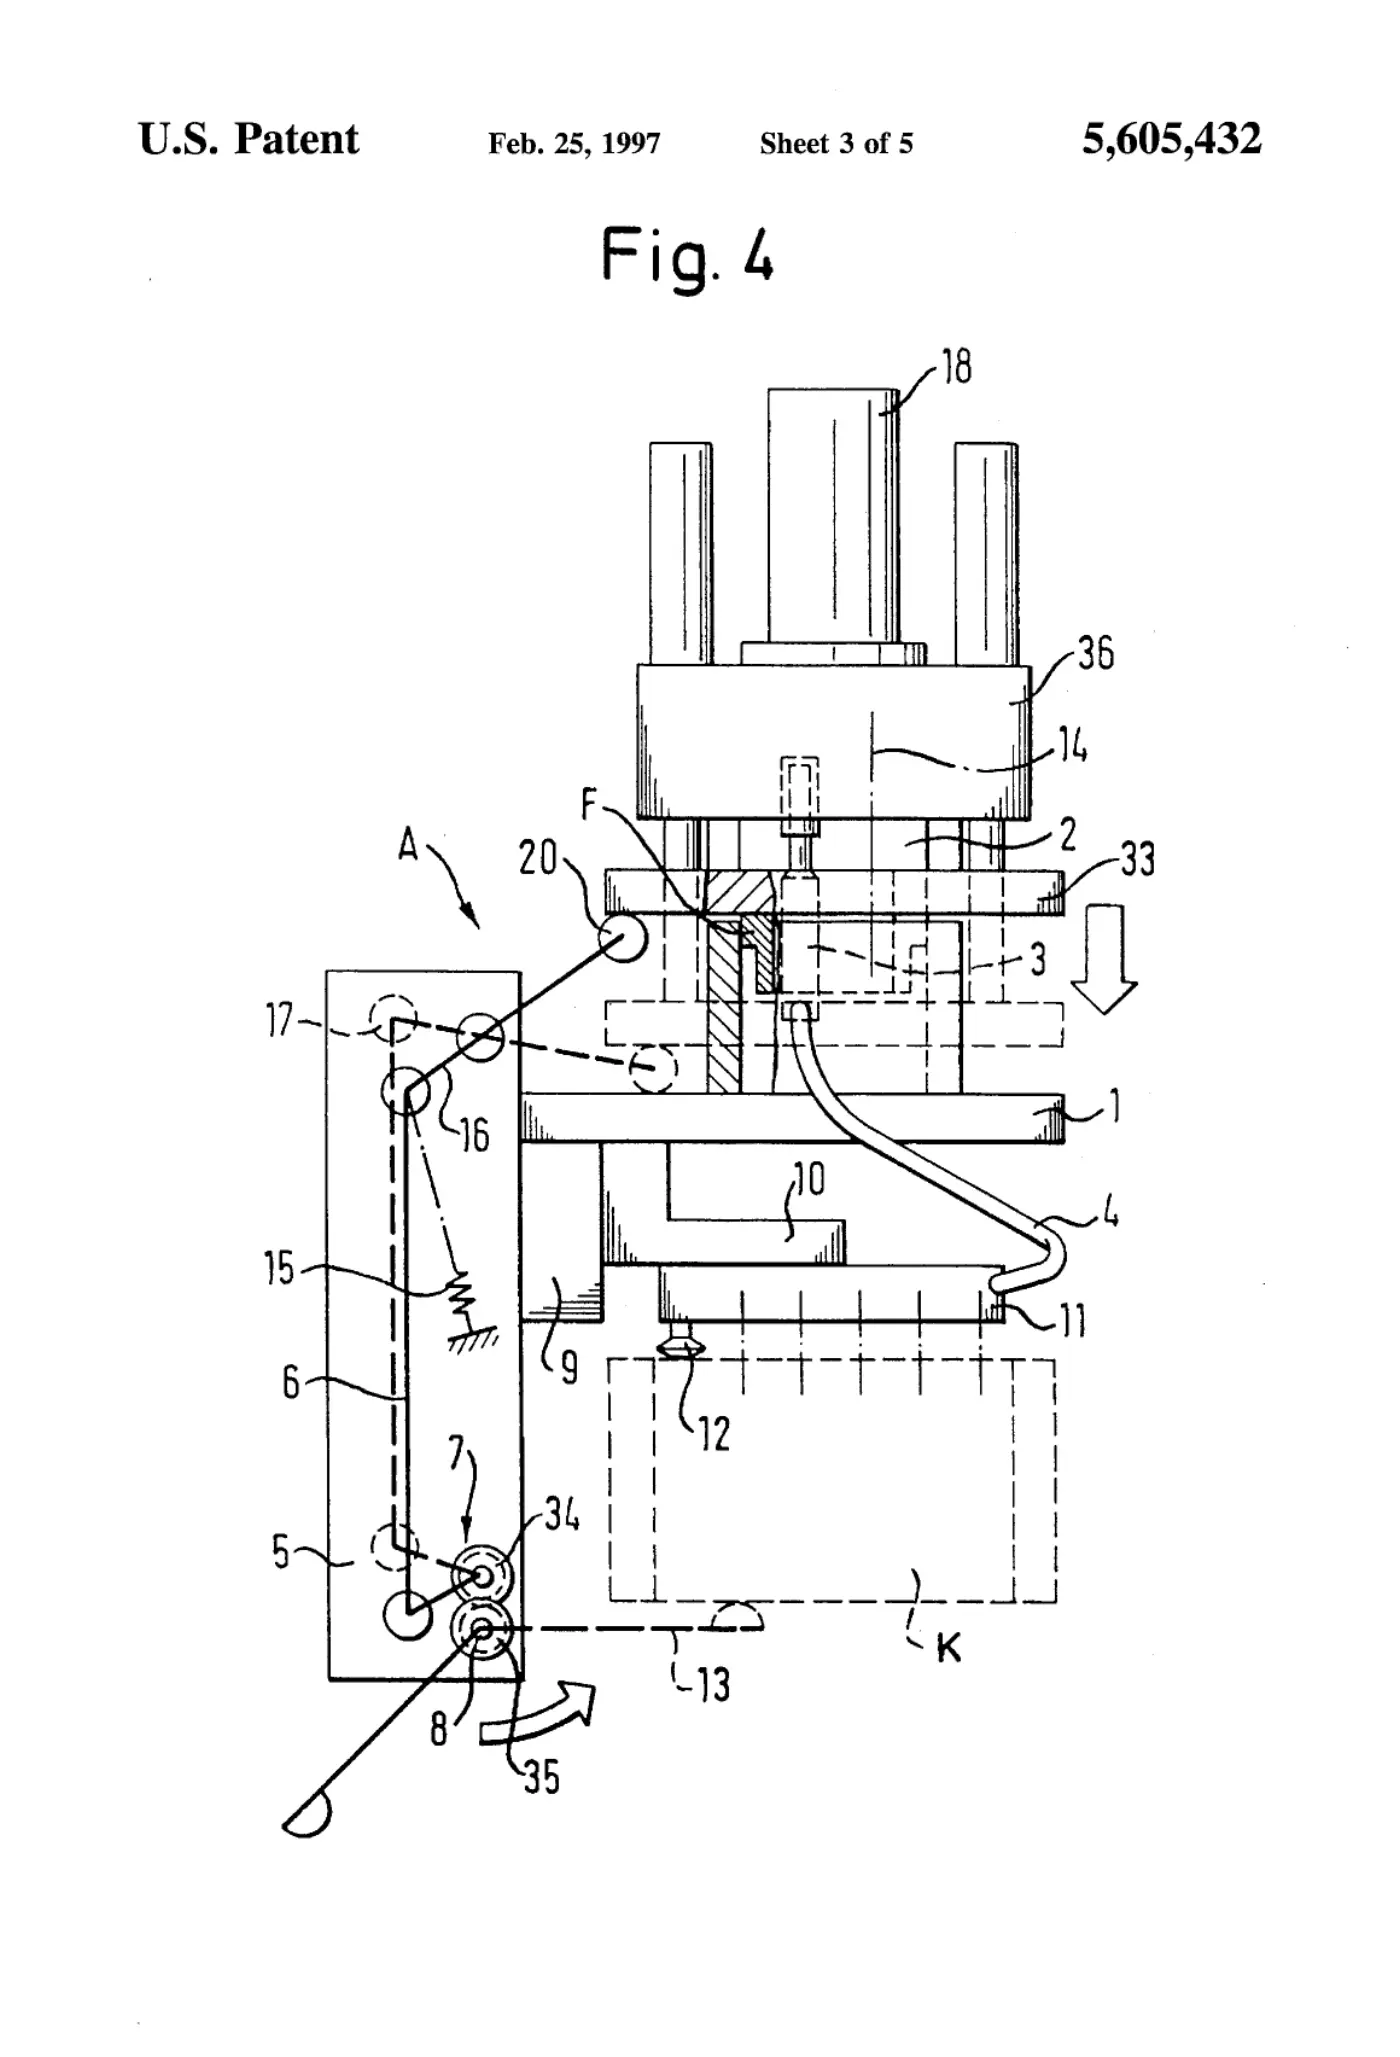
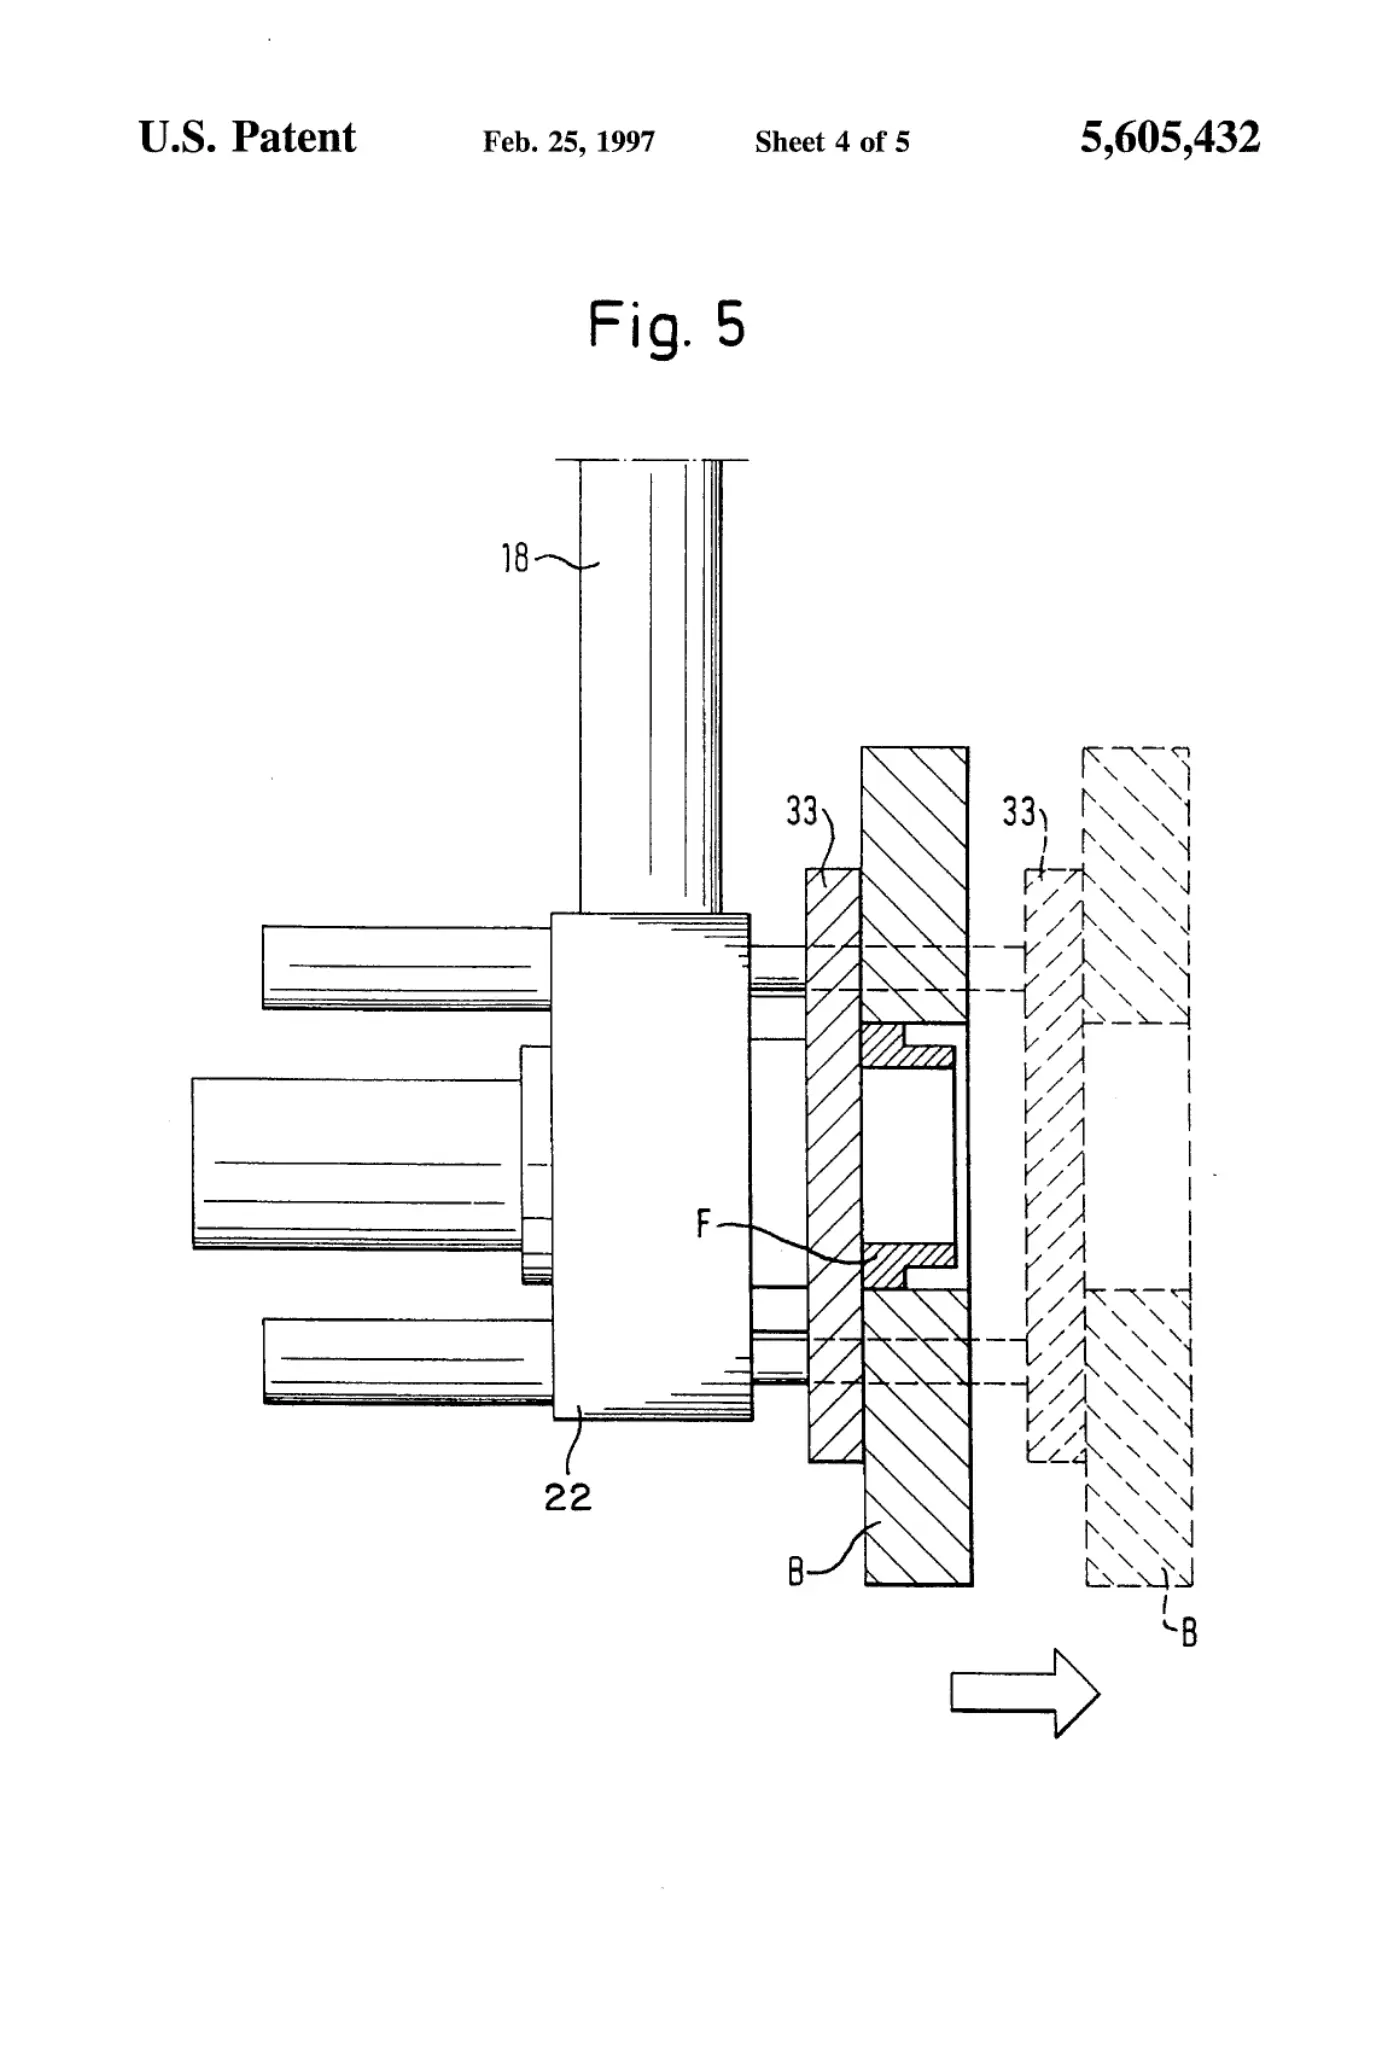
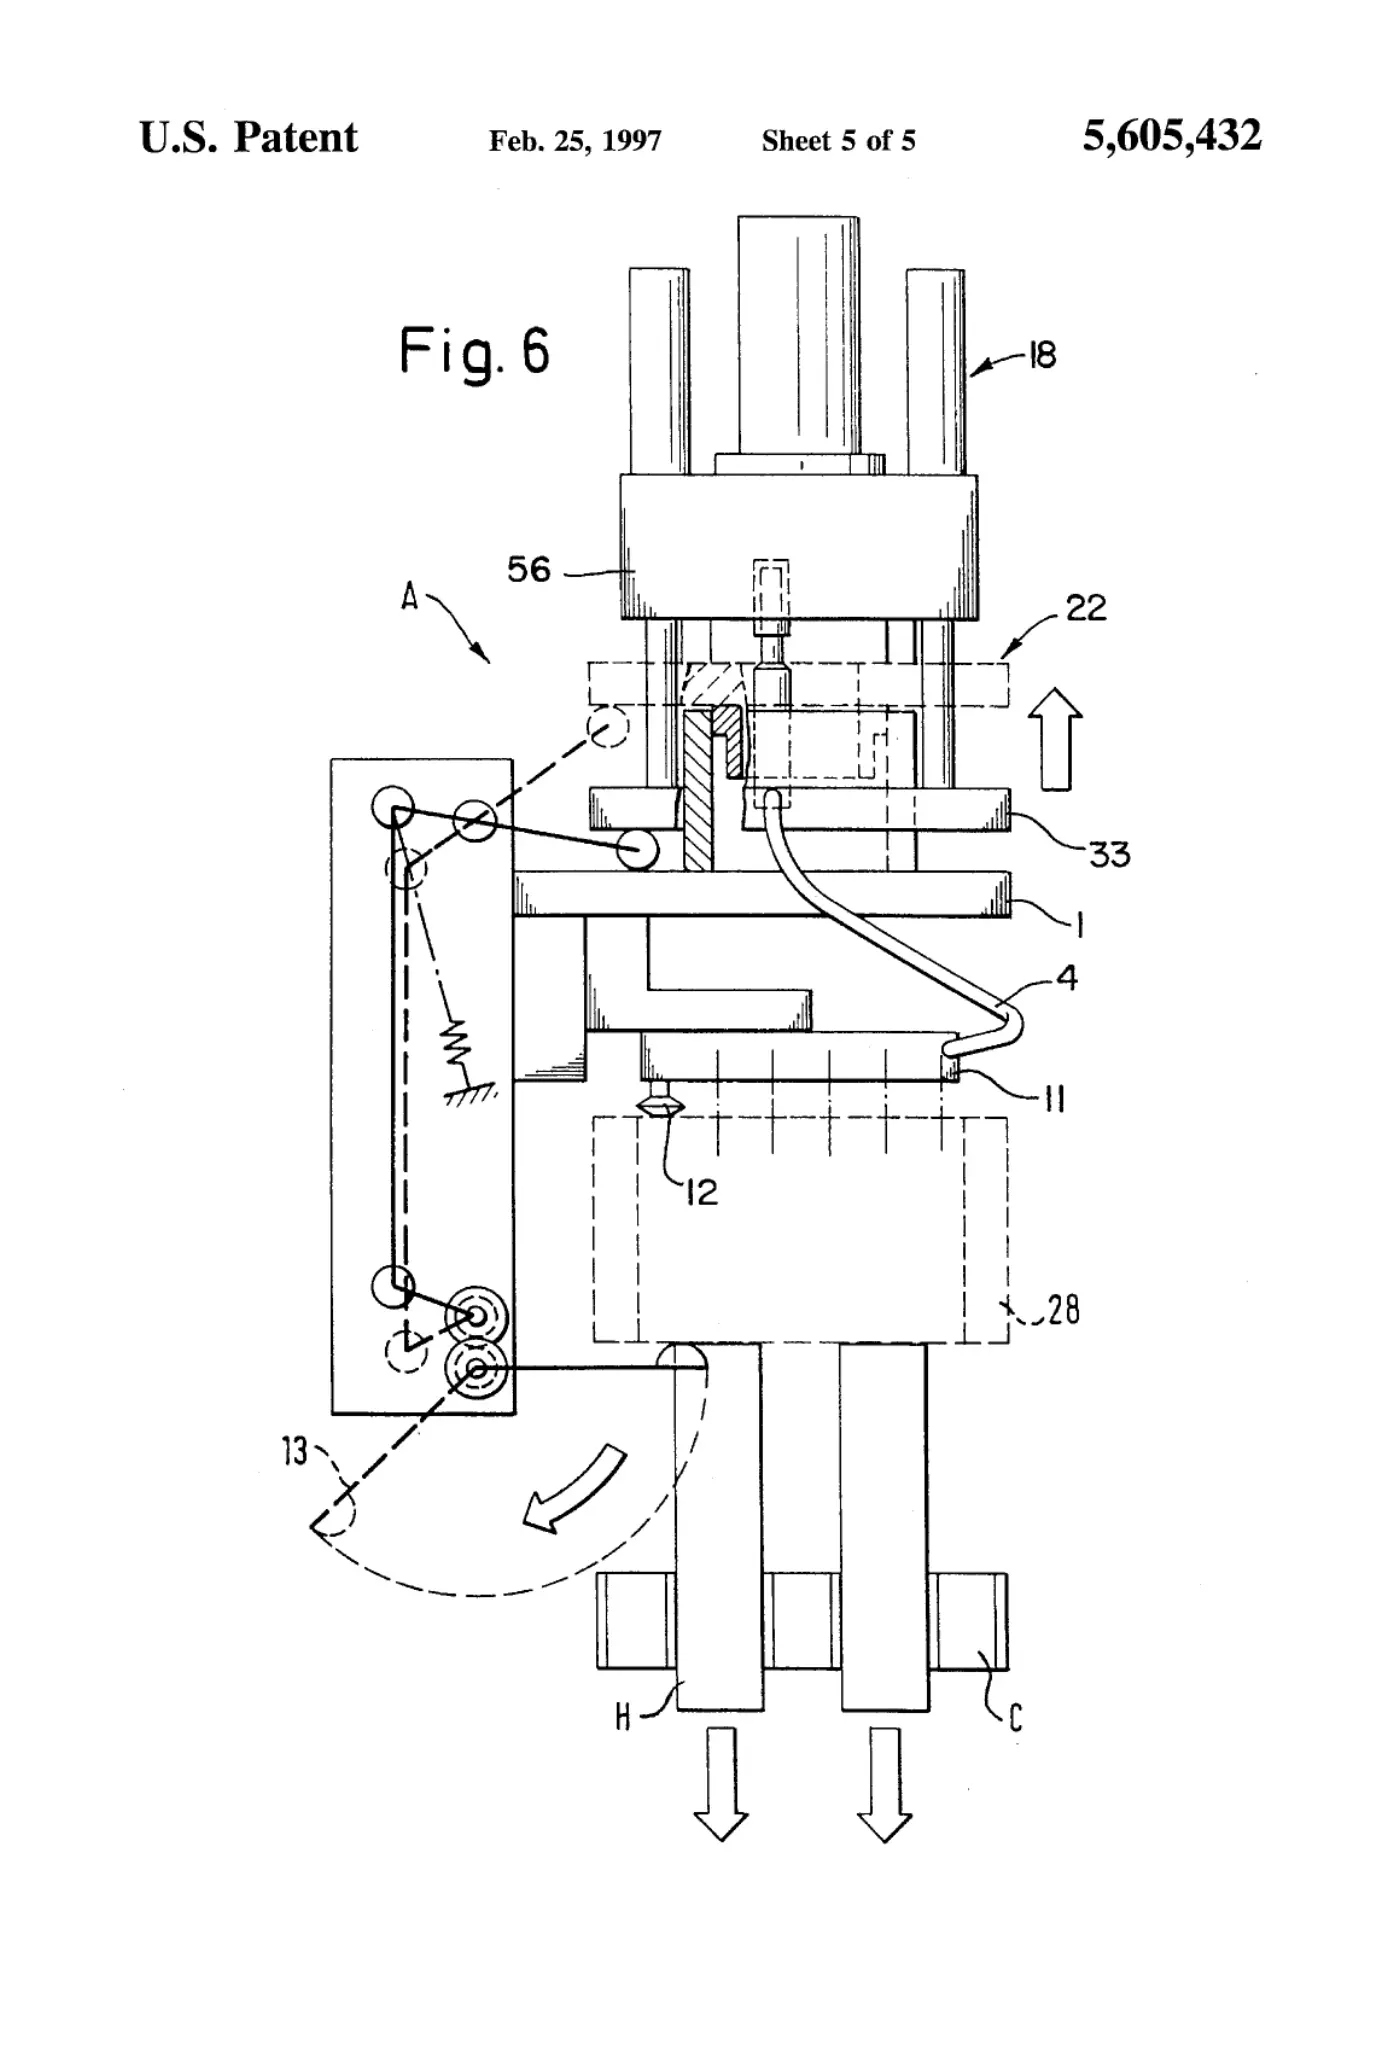
A robot manipulator has an arm with a head which is mounted for movement up and down, along a first horizontal path, along a second horizontal path at right angles to the first path, about a vertical axis and about a horizontal axis so that it can reach all portions of a storage facility for bobbins, stacked blanks and/or other commodities which are to be fed to one or more tobacco processing machines. The head has a jaw chuck which can engage a cylindrical internal surface of a bobbin or the cylindrical internal surface of a tool which is used for the transport of stacks of superimposed blanks of paper or the like. The head further has a vertically movable annular pusher which can strip a bobbin off the chuck or which can actuate one or more pivotable supports forming part of the tool and serving to prop one or more stacks from below. The tool is provided with suction heads which can lift one or more stacks off a pallet in the storage facility preparatory to pivoting of the support or supports to operative positions beneath the lifted stack or stacks. A vertically movable platform cooperates with a conveyor for transferred stacks or bobbins to accept the stacks from the tool preparatory to pivoting of the support or supports to their idle positions and to thereupon deposit the stack or stacks on the conveyor.
Abstract
A robot manipulator has an arm with a head which is mounted for movement up and down, along a first horizontal path, along a second horizontal path at right angles to the first path, about a vertical axis and about a horizontal axis so that it can reach all portions of a storage facility for bobbins, stacked blanks and/or other commodities which are to be fed to one or more tobacco processing machines. The head has a jaw chuck which can engage a cylindrical internal surface of a bobbin or the cylindrical internal surface of a tool which is used for the transport of stacks of superimposed blanks of paper or the like. The head further has a vertically movable annular pusher which can strip a bobbin off the chuck or which can actuate one or more pivotable supports forming part of the tool and serving to prop one or more stacks from below. The tool is provided with suction heads which can lift one or more stacks off a pallet in the storage facility preparatory to pivoting of the support or supports to operative positions beneath the lifted stack or stacks. A vertically movable platform cooperates with a conveyor for transferred stacks or bobbins to accept the stacks from the tool preparatory to pivoting of the support or supports to their idle positions and to thereupon deposit the stack or stacks on the conveyor.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
[0005]Sheet 5.
Publication information
Citation
OpenTechnical Publication OT-2026-000003267, “Robot manipulator,” published September 15, 2026 at 19:58:50 UTC, https://opentechnical.org/p/OT-2026-000003267.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.