OT-2026-000003275
Control for hydraulically operated construction machine having multiple tandem articulated members
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003275
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- STEENWYK TIMOTHY E, WALSTRA ERIC J
- Assignee
- LASER ALIGNMENT
- Original source
- US-5572809-A, the United States Patent and Trademark Office, 12 November 1996
- Document SHA-256
- 184f67cba30fabe07347c63979c1260dfcb8db19e2291ca0186418607c7b645a
An apparatus and method for controlling a hydraulically operated construction machine, having a plurality of tandem articulated members which are controlled in a manner that movement of one of the members is controlled in response to movement of another of the members, in order to move the members in a predetermined pattern. The members are controlled in response to the anticipated future movement of the another member. Anticipated future movement of the another member may be determined, for example, as a function of the present position and velocity of the another member and system delay in movement of the another member. Where the another member is controlled manually by an operator control lever coupled with a manual hydraulic control valve, anticipated future movement may be determined by monitoring actuation of the control lever.
Abstract
An apparatus and method for controlling a hydraulically operated construction machine, having a plurality of tandem articulated members which are controlled in a manner that movement of one of the members is controlled in response to movement of another of the members, in order to move the members in a predetermined pattern. The members are controlled in response to the anticipated future movement of the another member. Anticipated future movement of the another member may be determined, for example, as a function of the present position and velocity of the another member and system delay in movement of the another member. Where the another member is controlled manually by an operator control lever coupled with a manual hydraulic control valve, anticipated future movement may be determined by monitoring actuation of the control lever.
1. Drawings
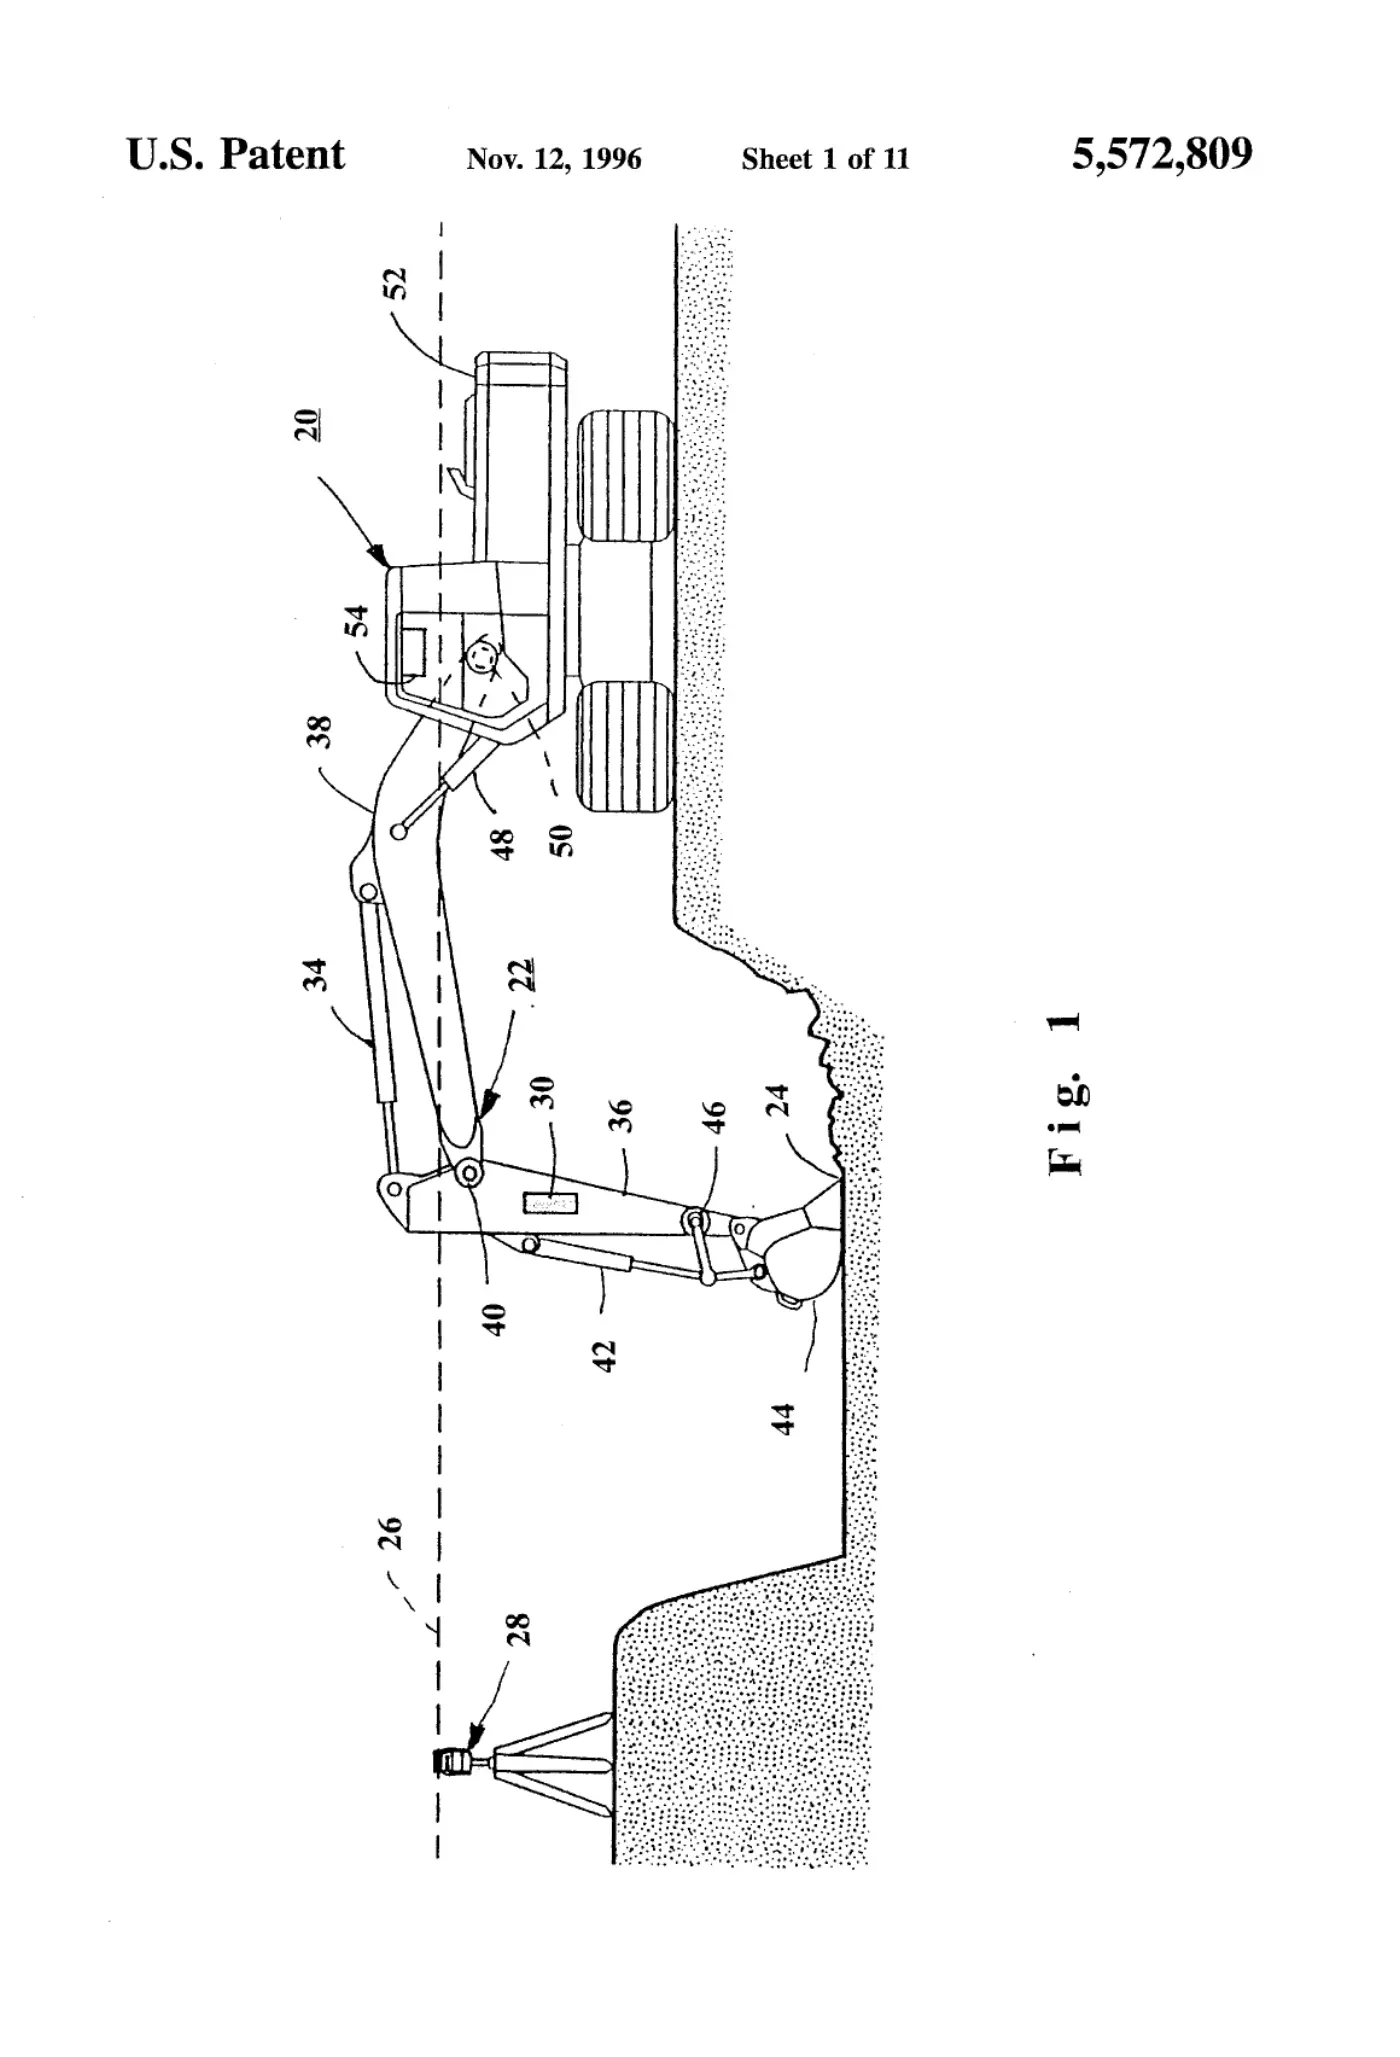
[0001]Sheet 1.
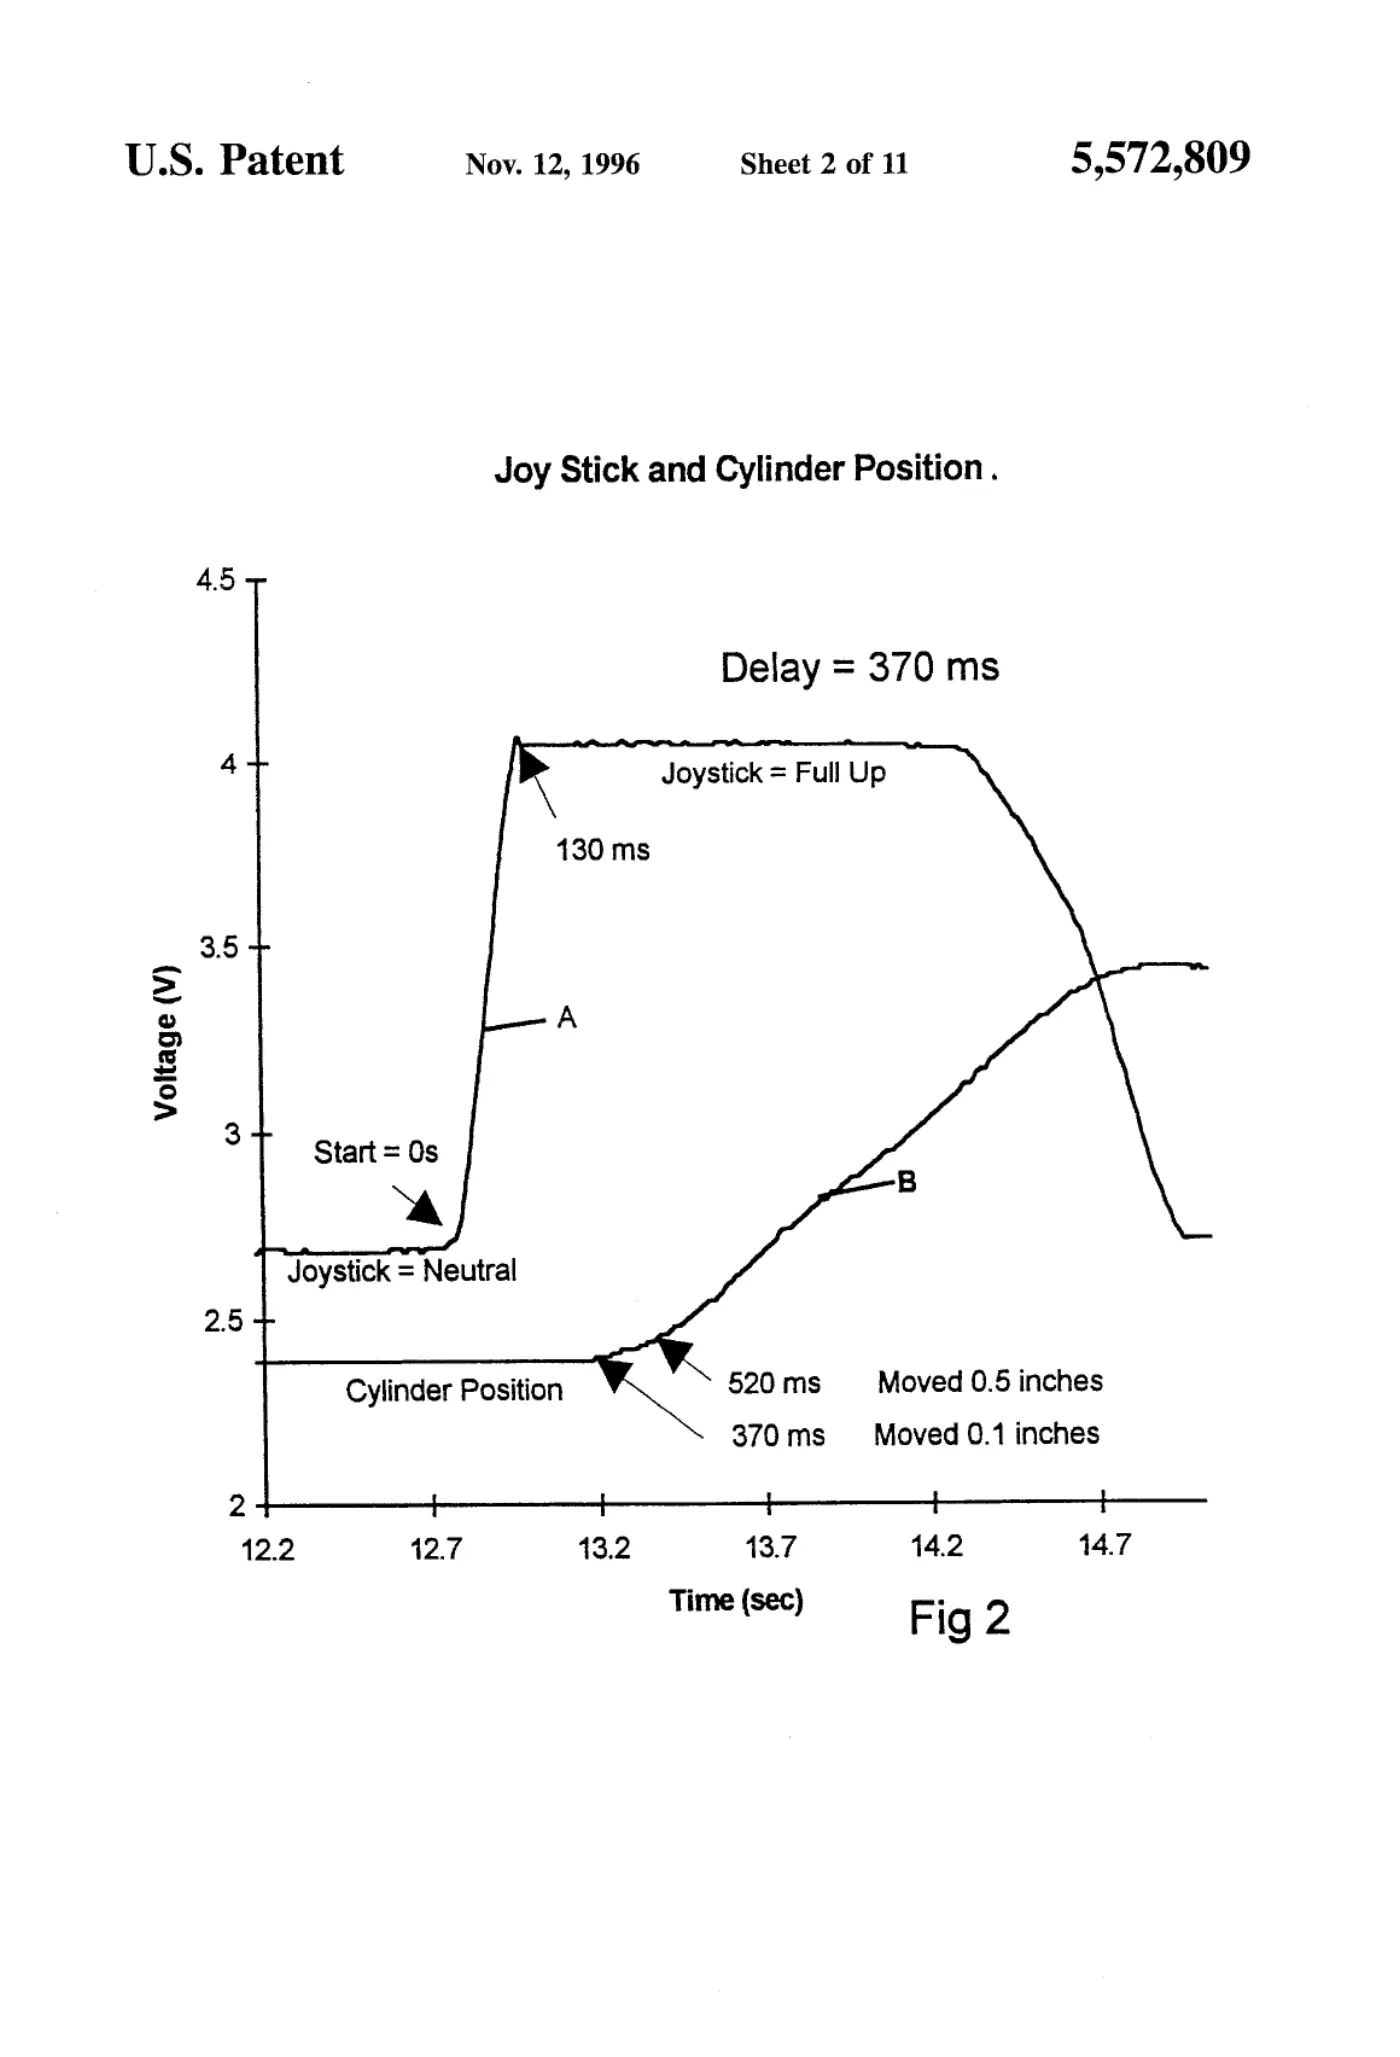
[0002]Sheet 2.
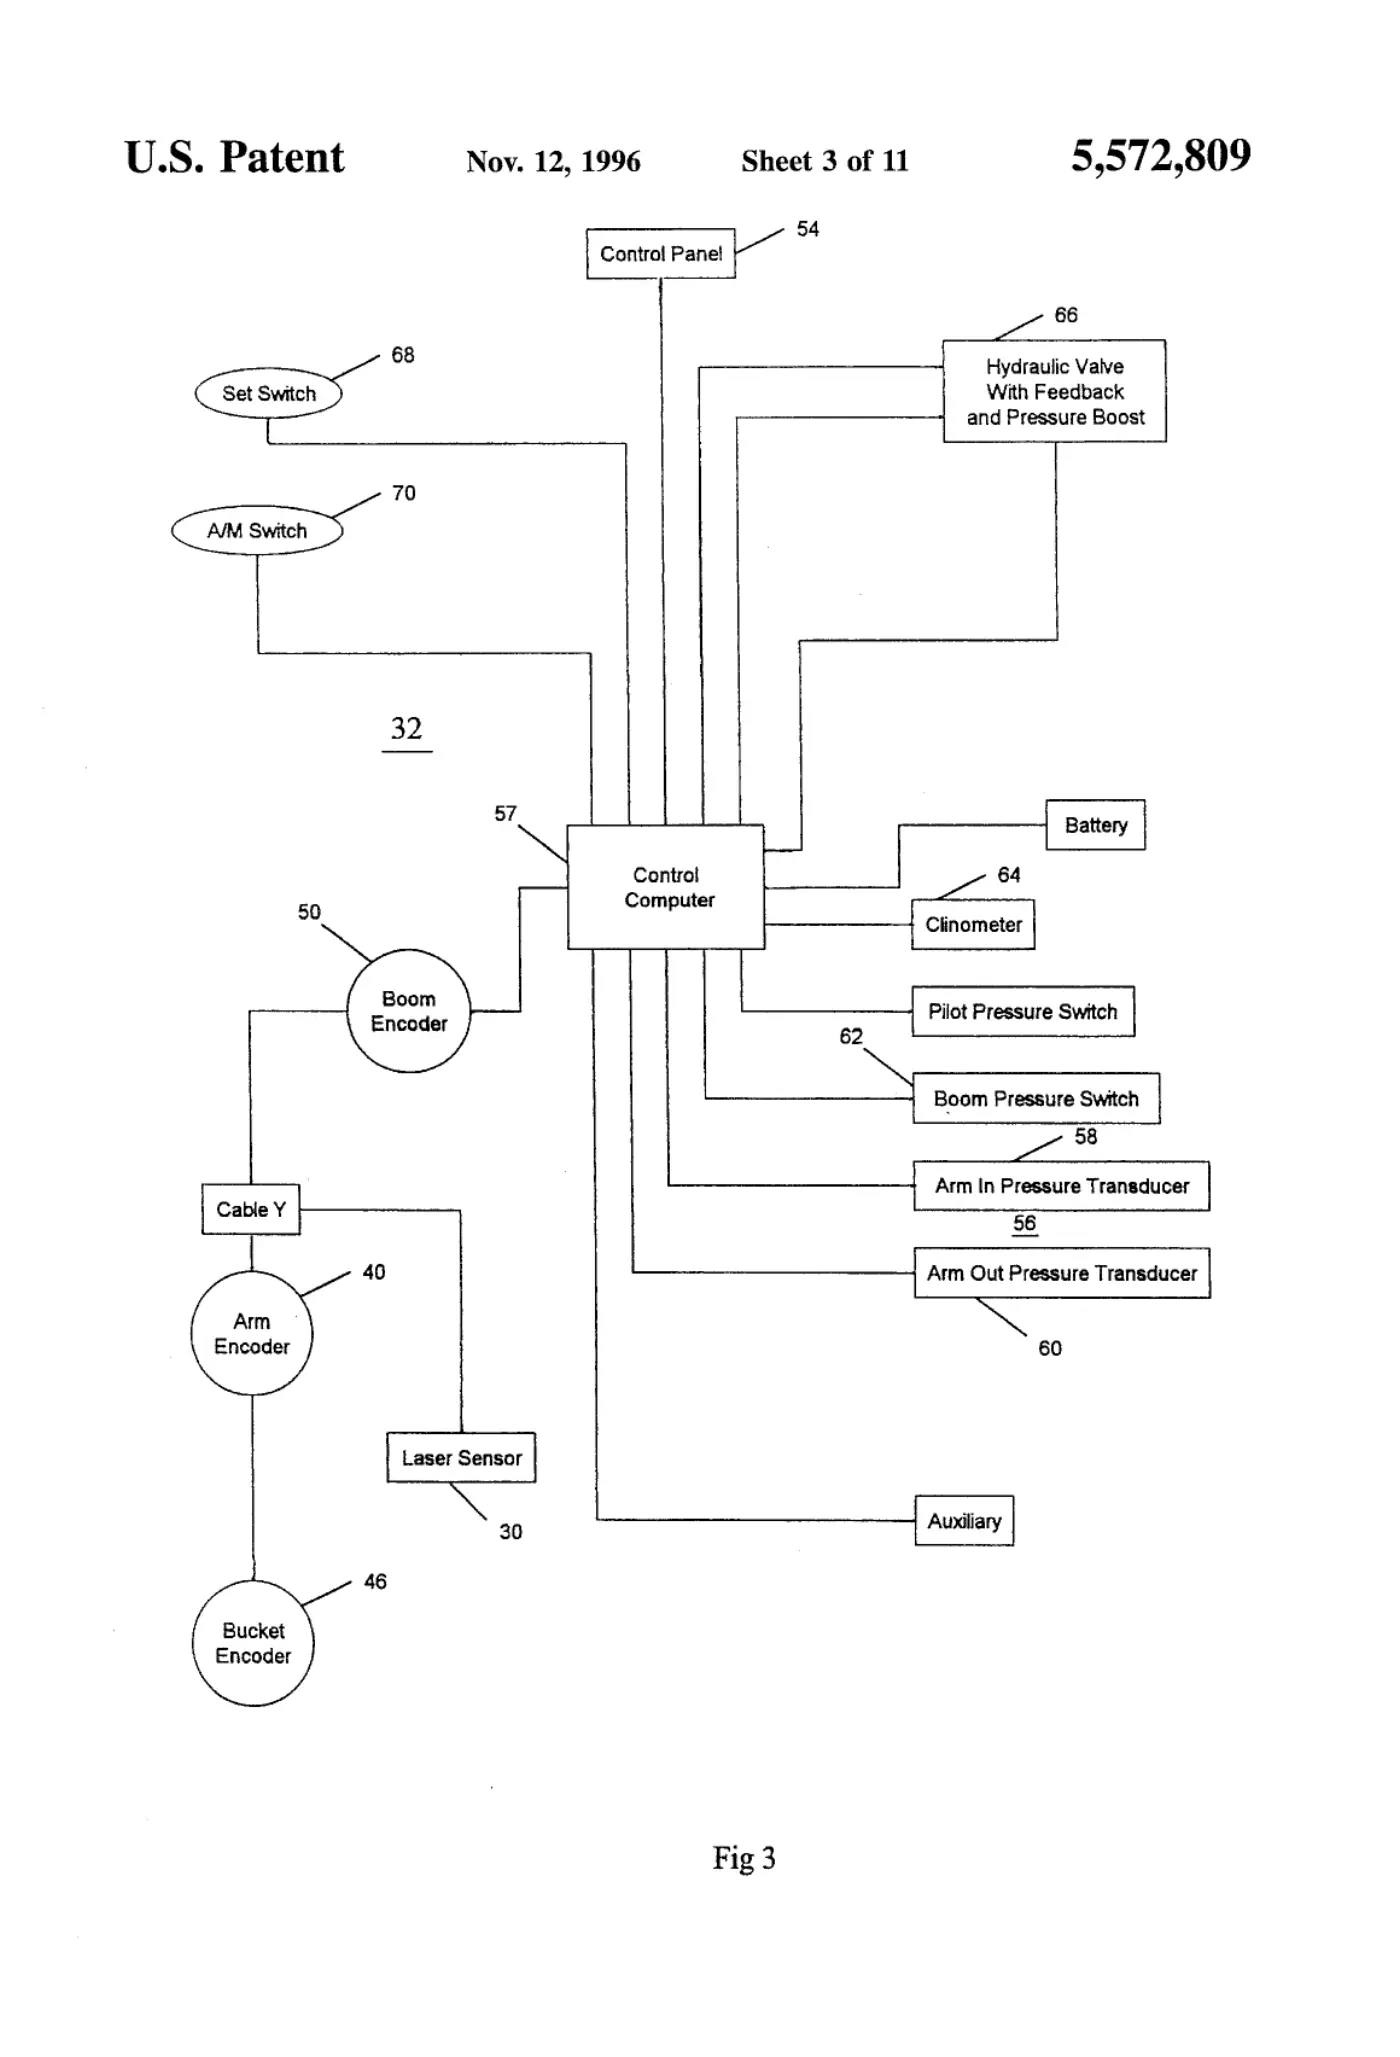
[0003]Sheet 3.
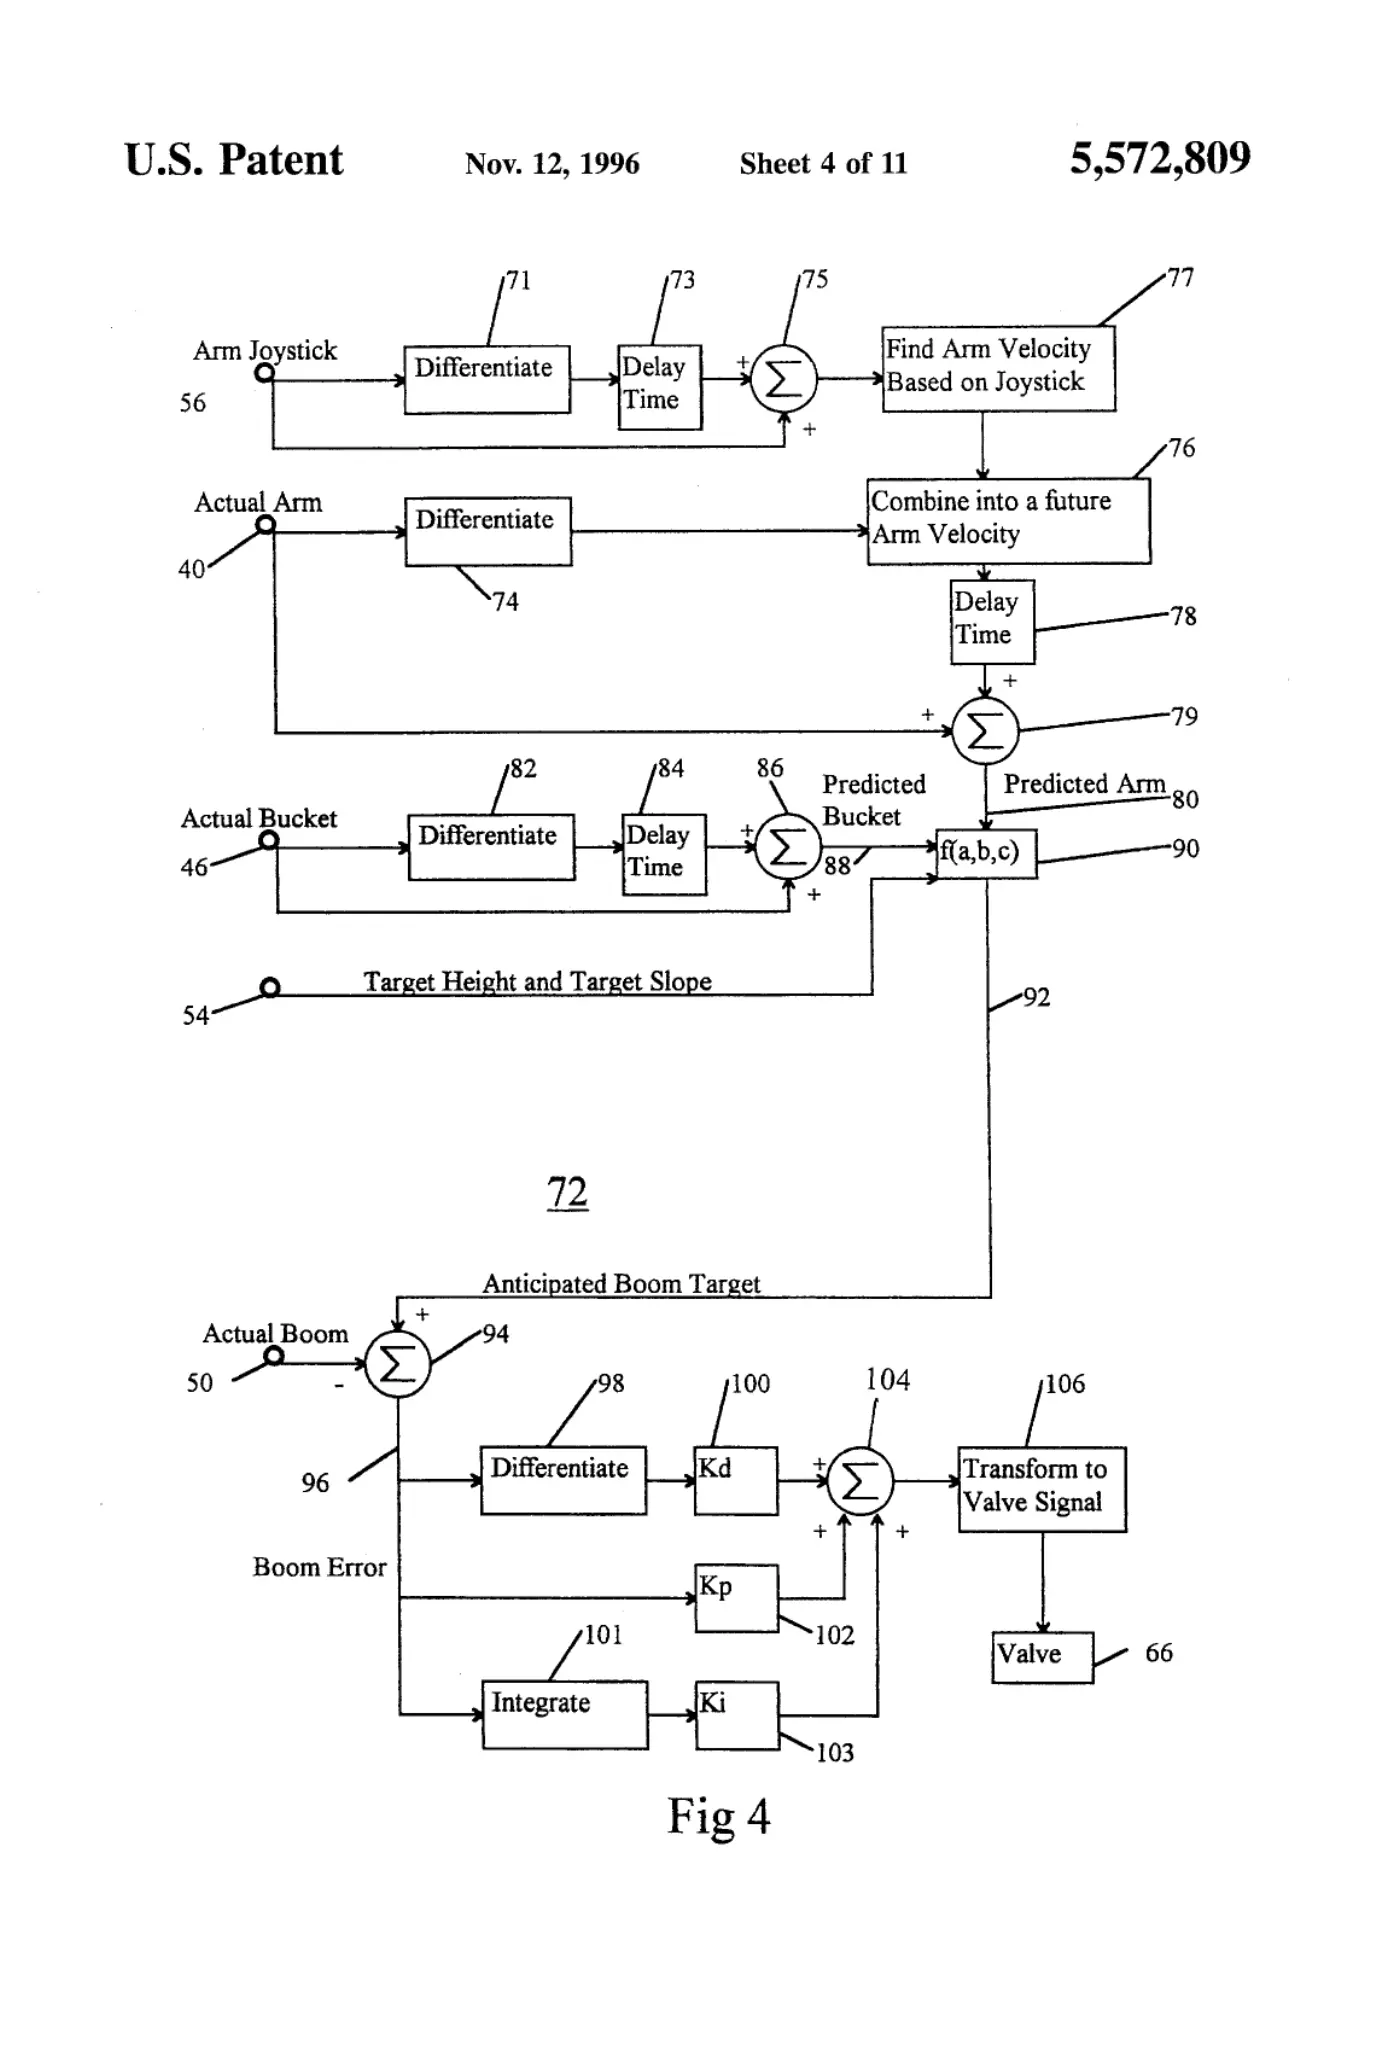
[0004]Sheet 4.
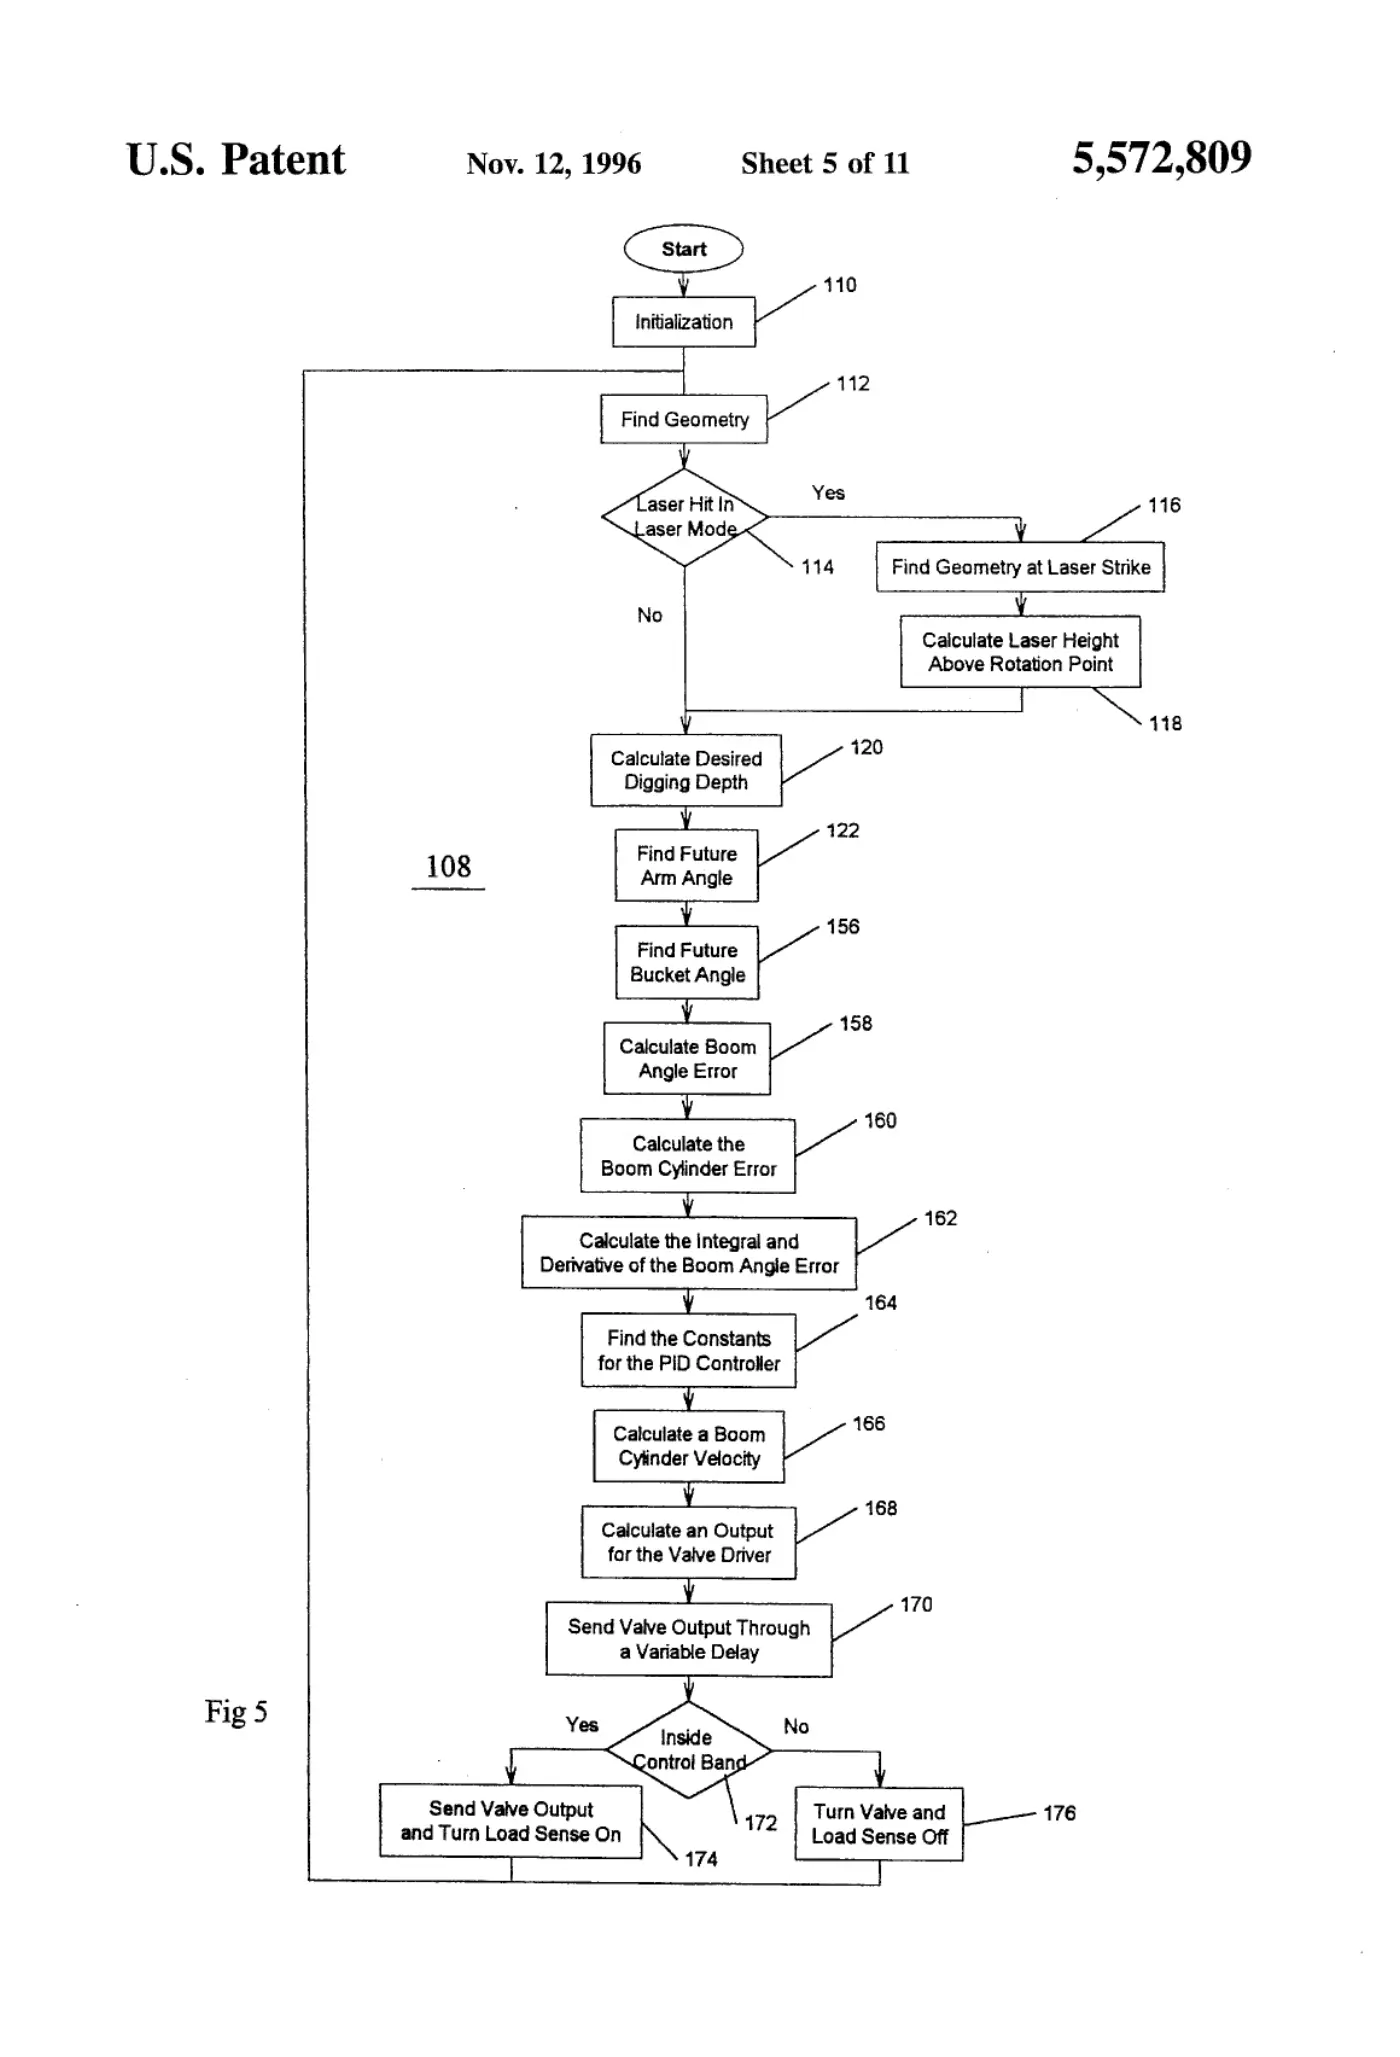
[0005]Sheet 5.
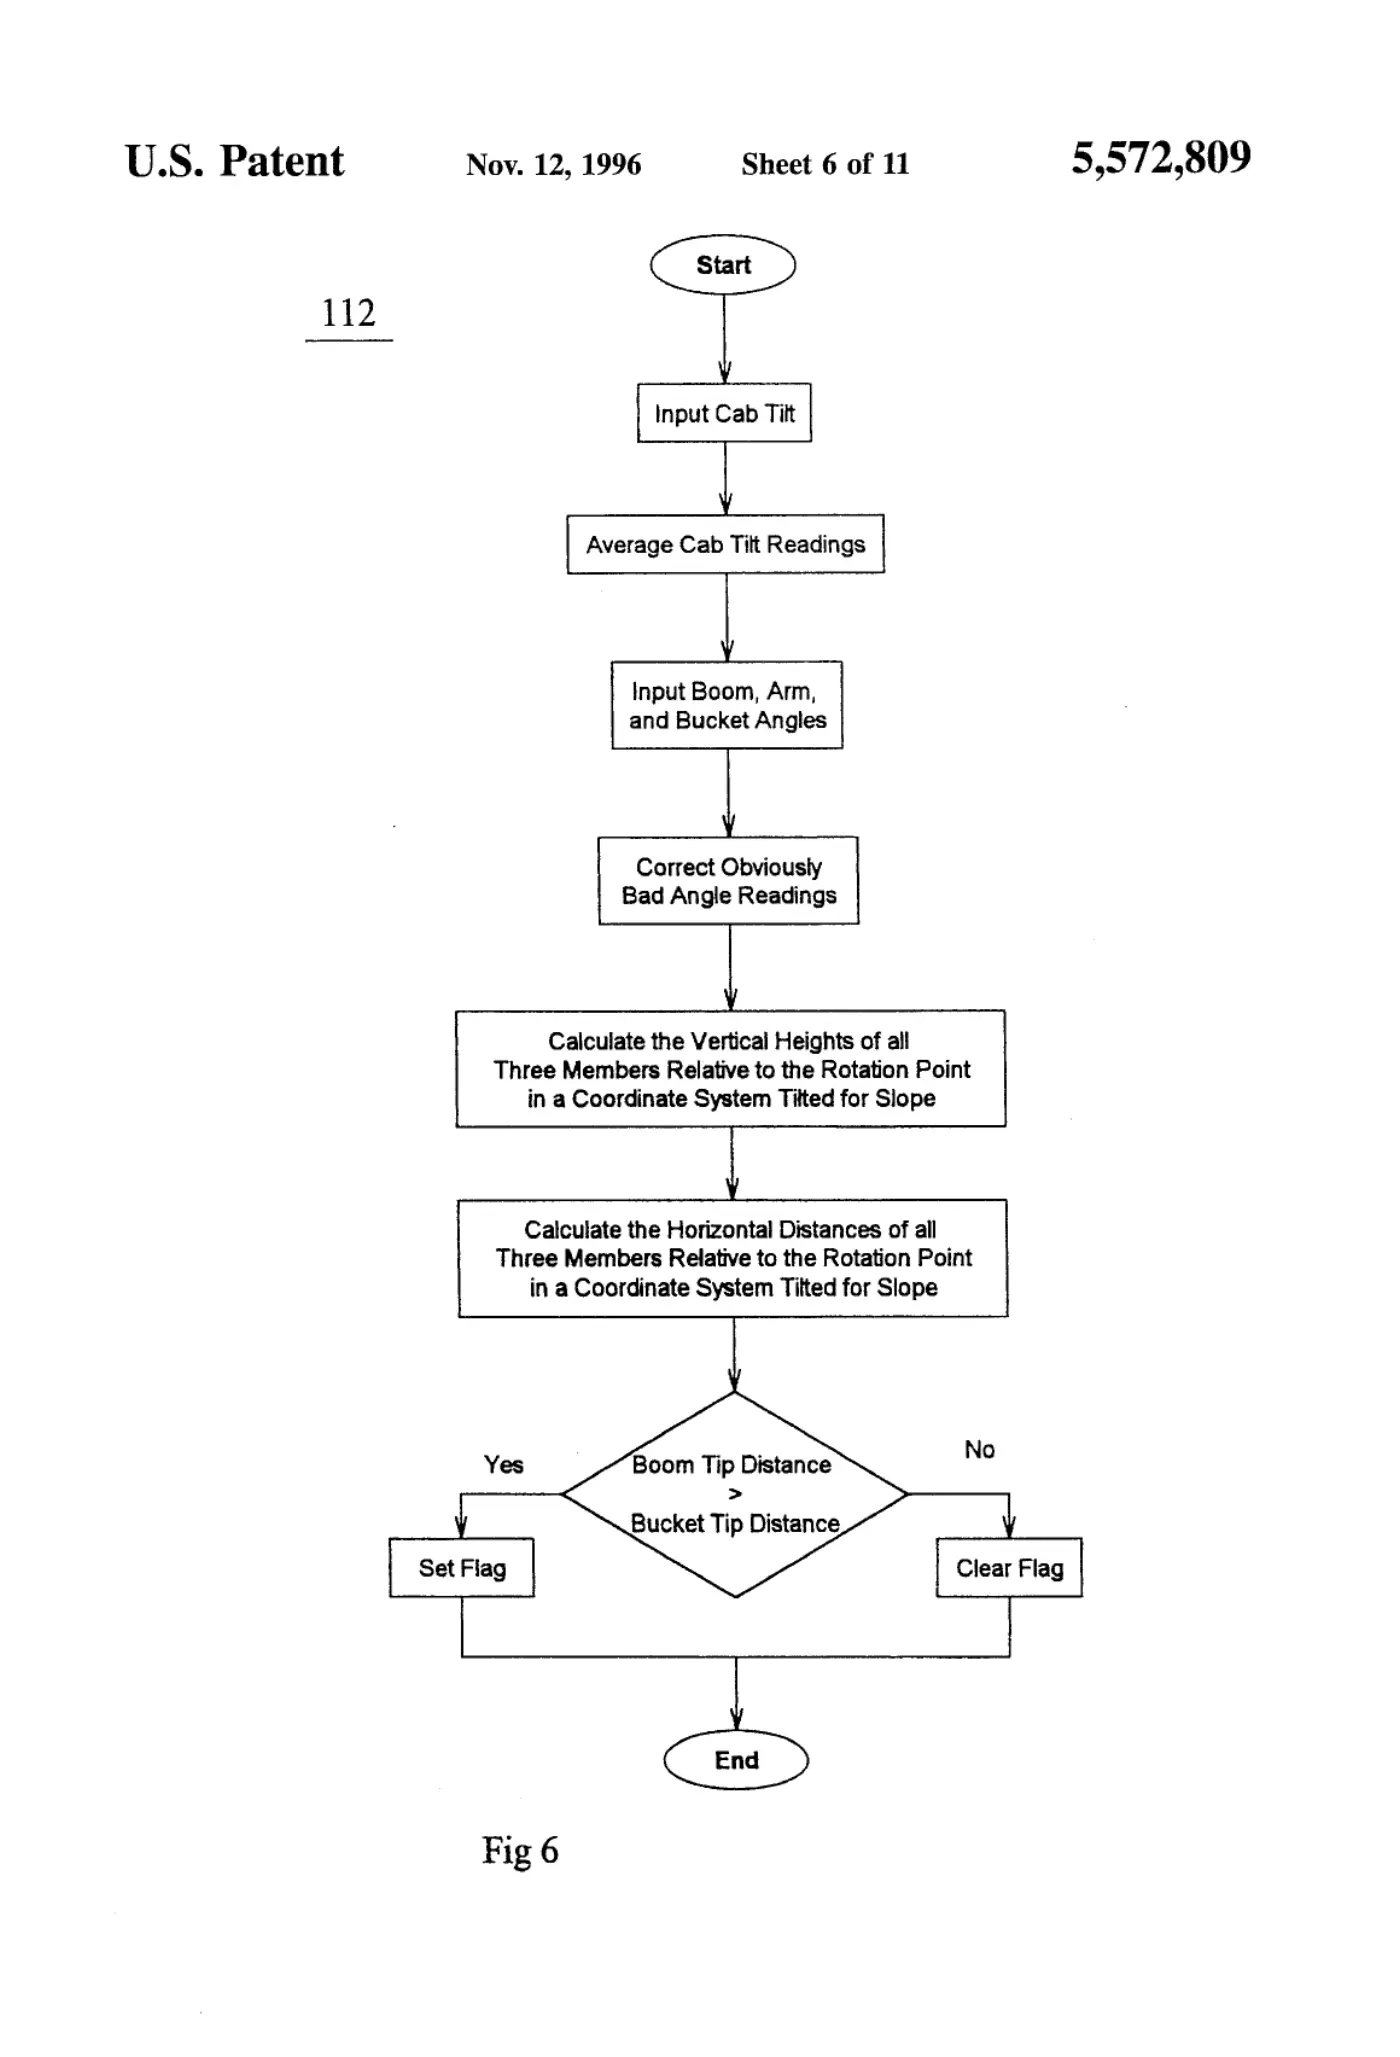
[0006]Sheet 6.
[0007]Sheet 7.
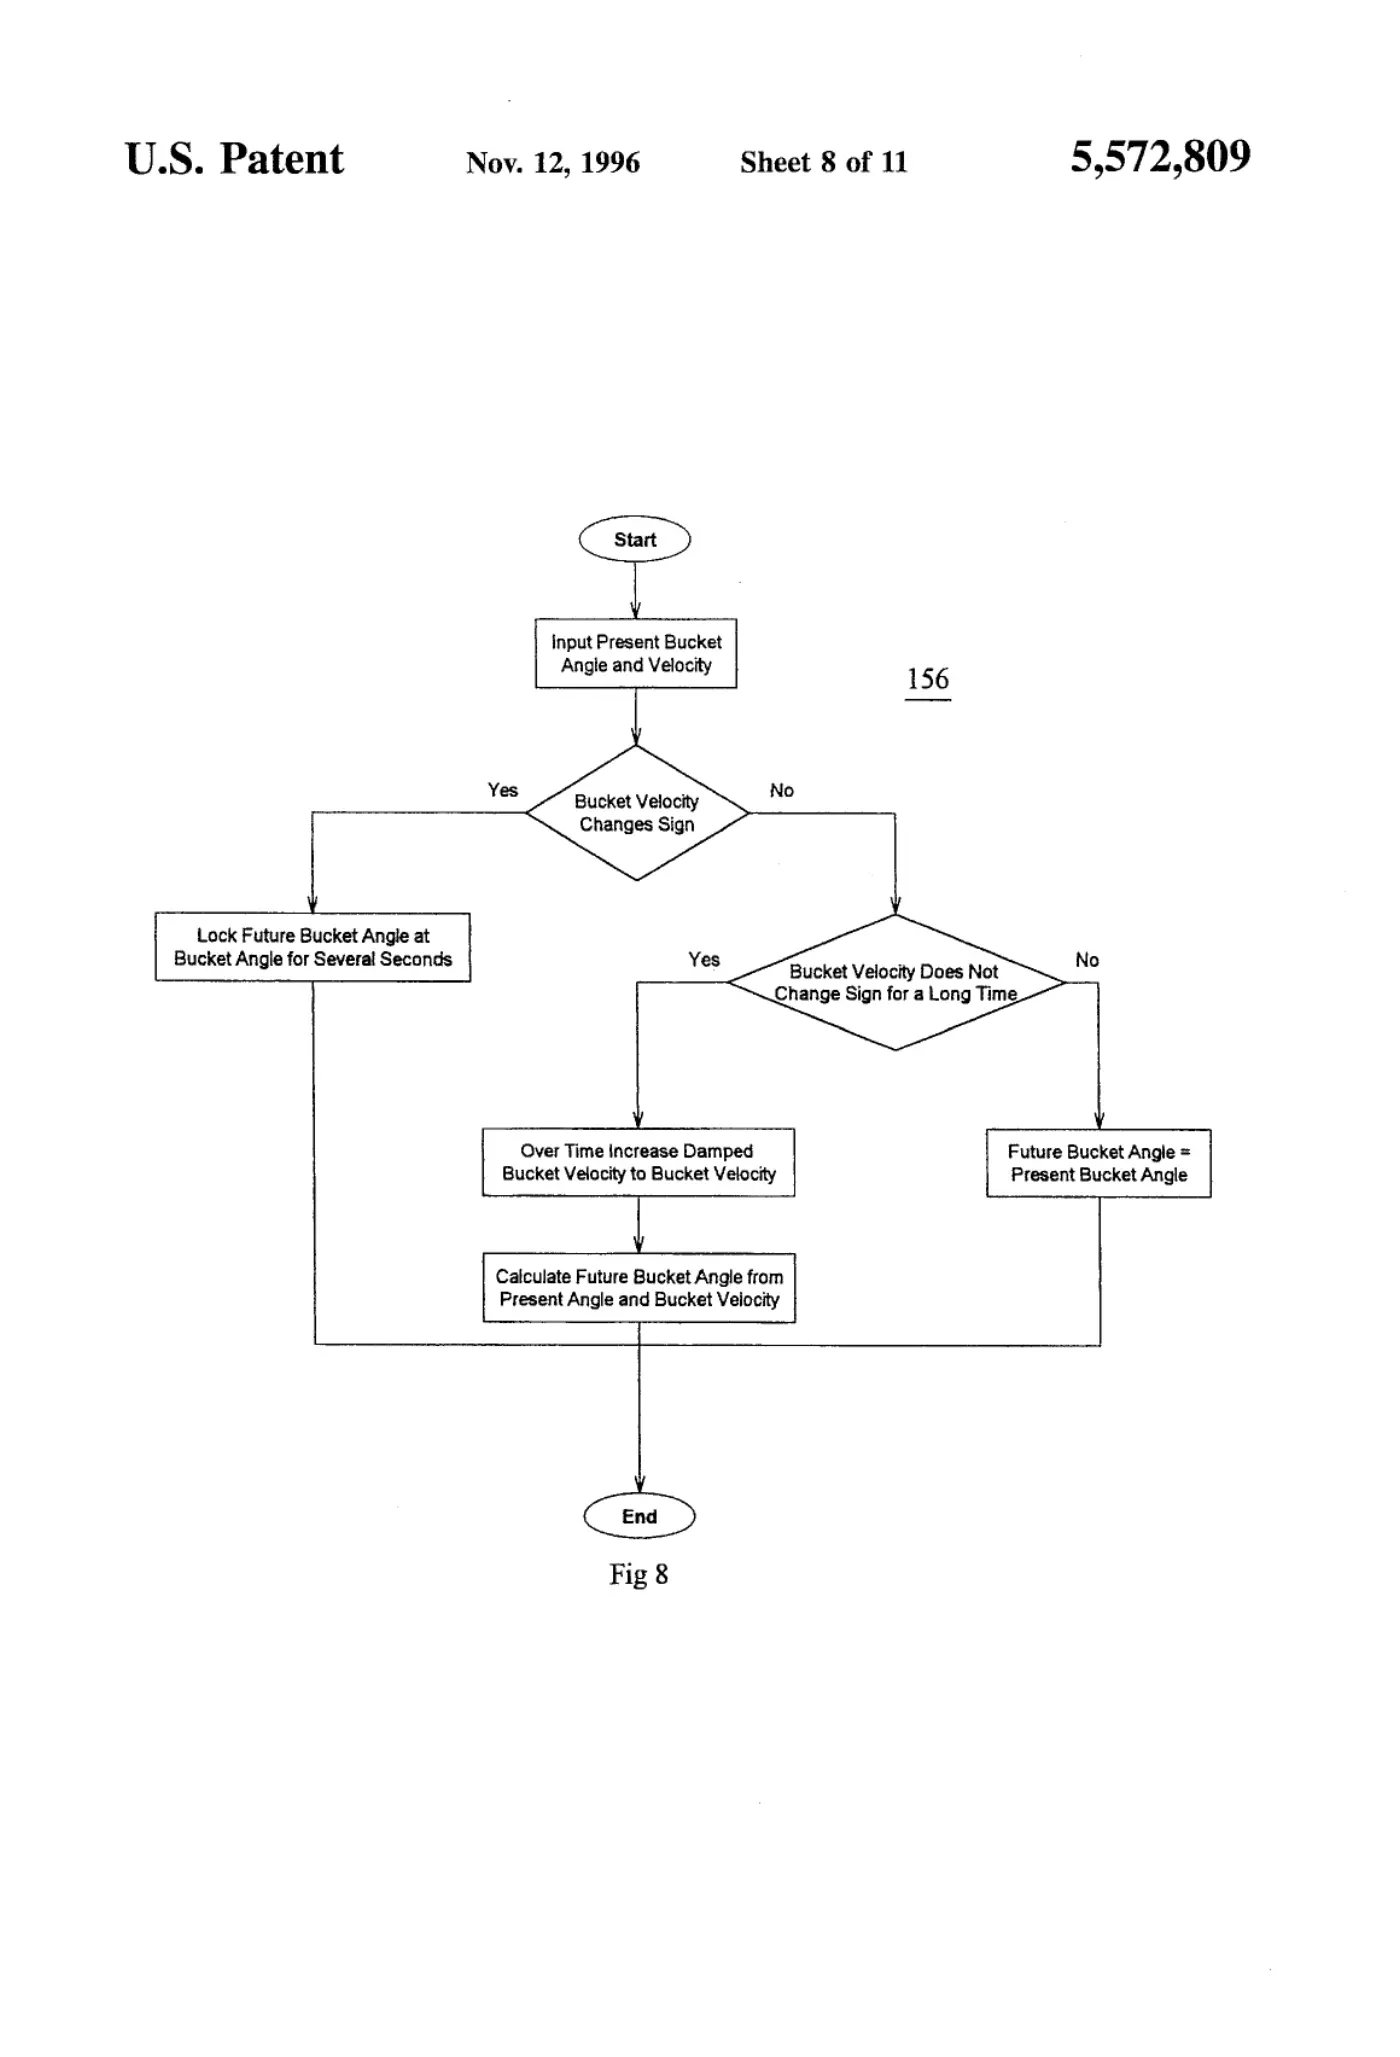
[0008]Sheet 8.
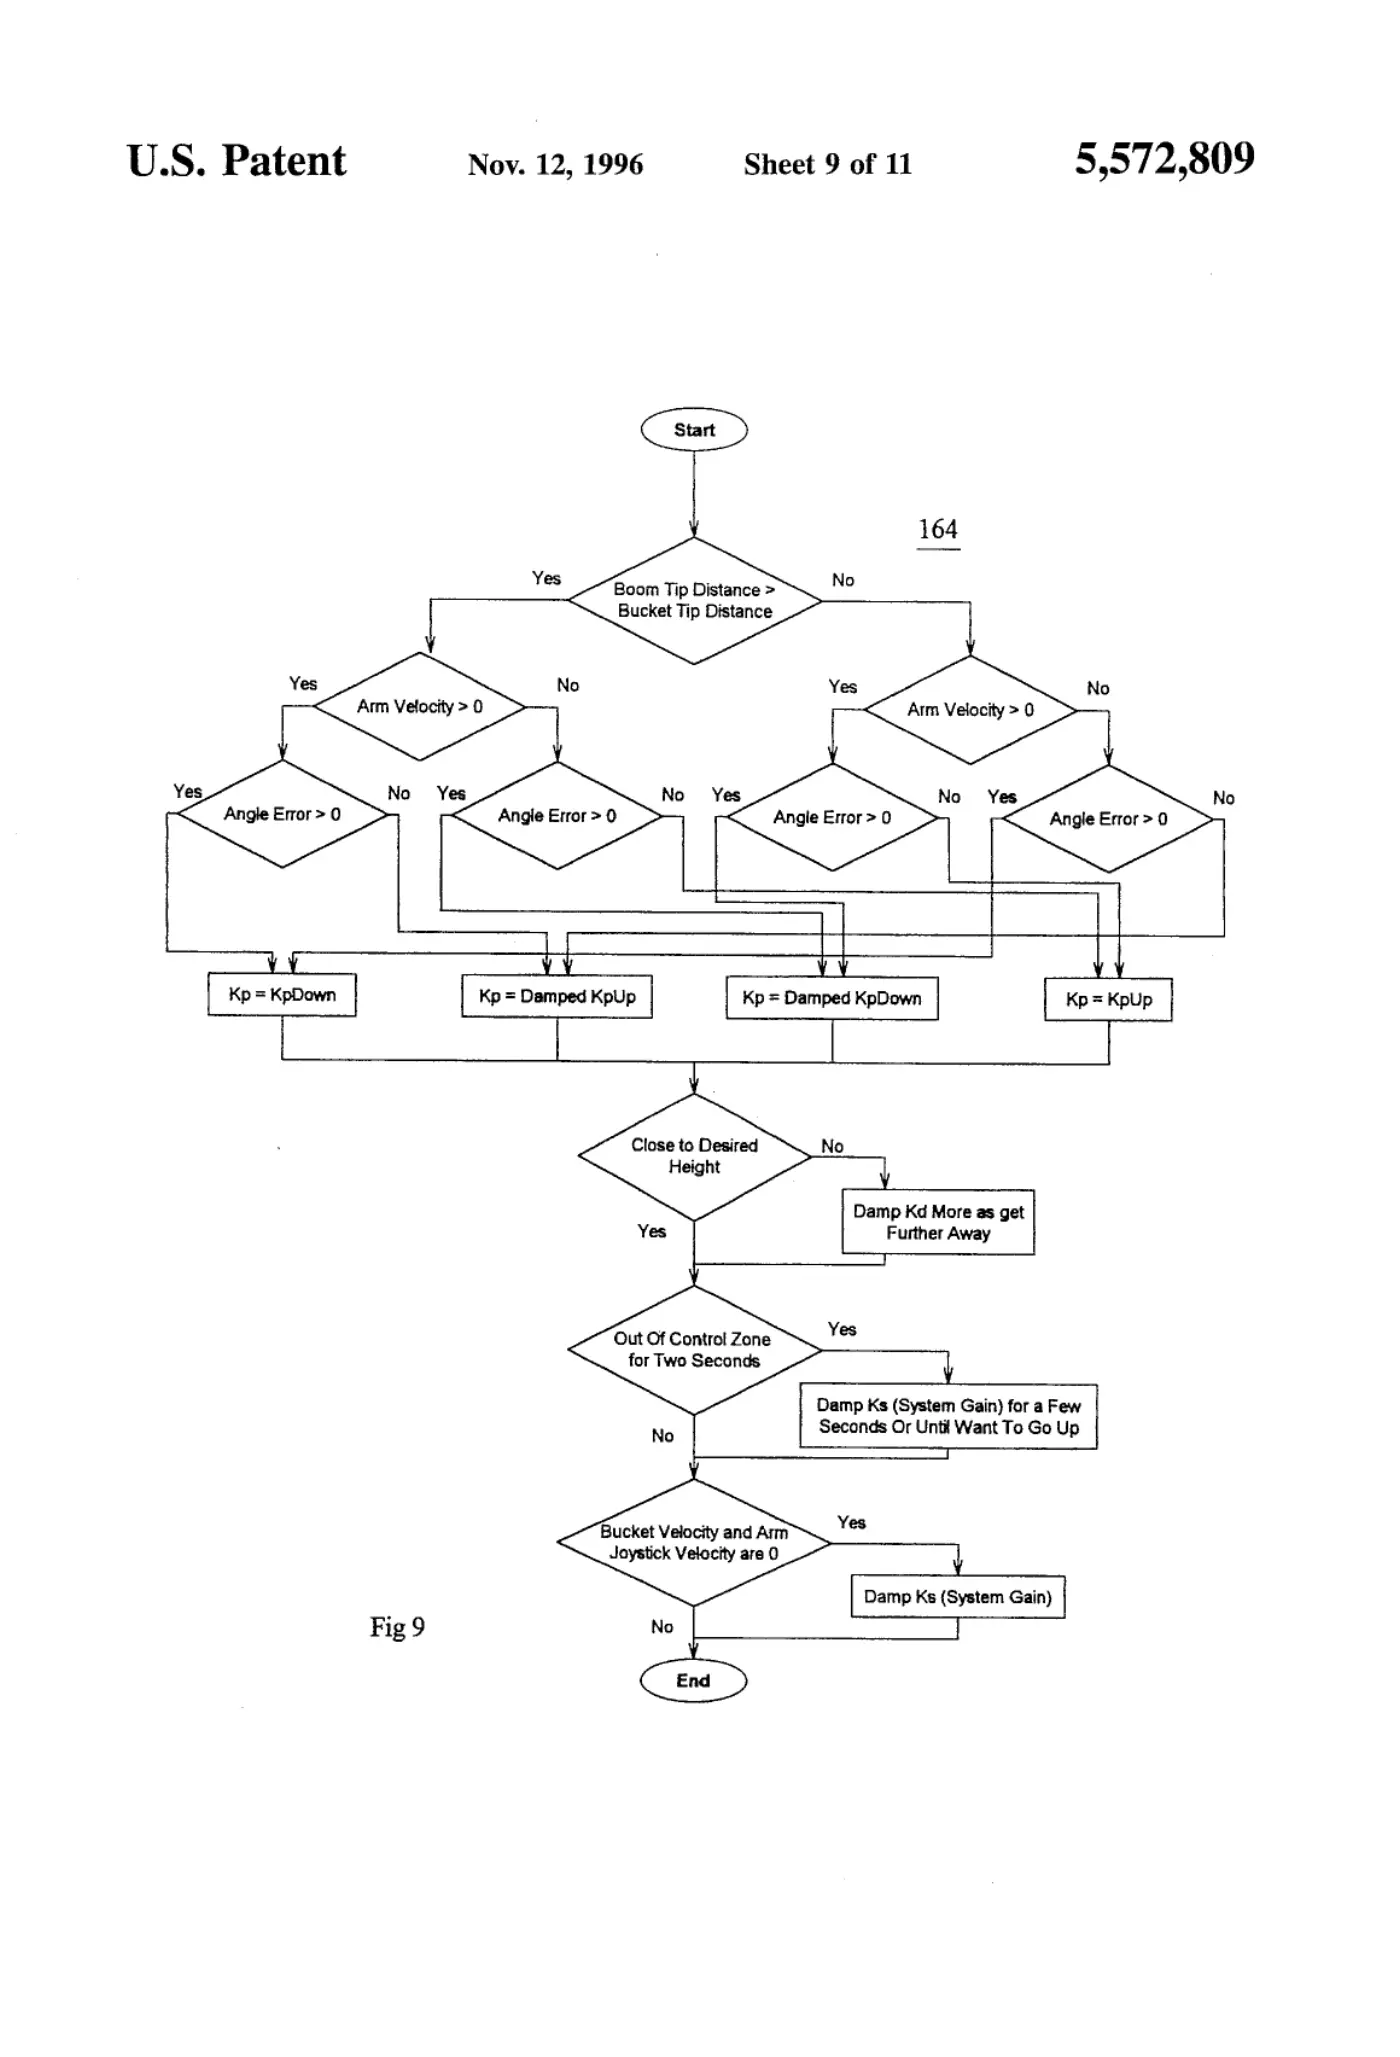
[0009]Sheet 9.
Publication information
Citation
OpenTechnical Publication OT-2026-000003275, “Control for hydraulically operated construction machine having multiple tandem articulated members,” published September 15, 2026 at 20:00:33 UTC, https://opentechnical.org/p/OT-2026-000003275.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.