OT-2026-000003283
Modular, expandable and reconfigurable robot
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003283
- Classification
- Robotics & Automation › Robot Architectures
- Assignee
- ENGINEERING SERVICES INC
- Original source
- US-5523662-A, the United States Patent and Trademark Office, 4 June 1996
- Document SHA-256
- a3e53c00b9523ac429a5e6cb1578ff07640c93cc03e2c1eb1ad05edc5d4e81f0
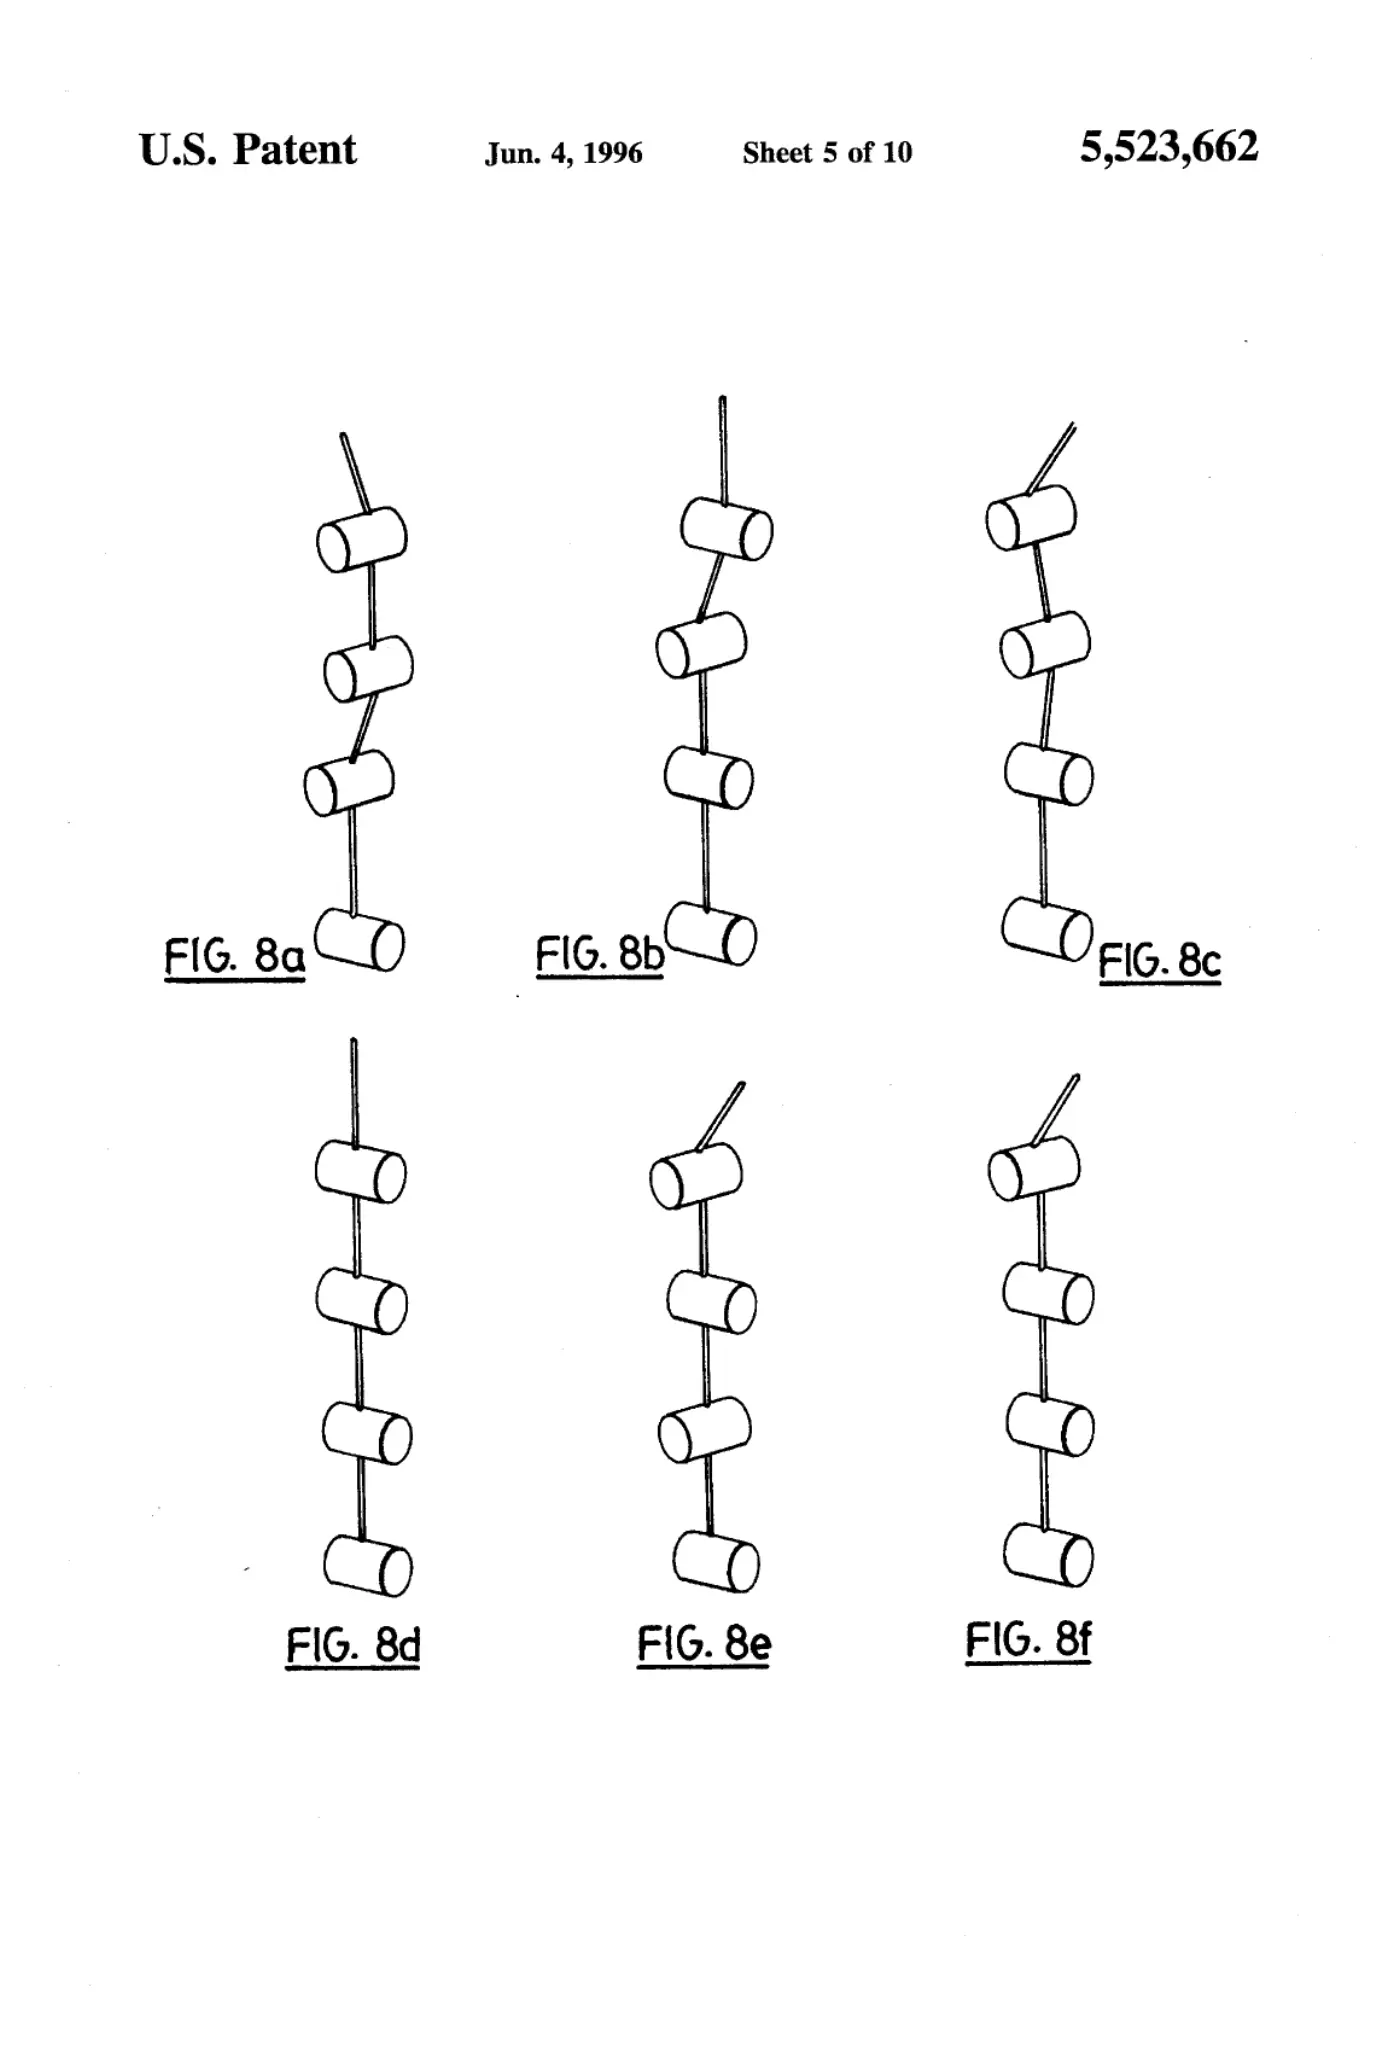
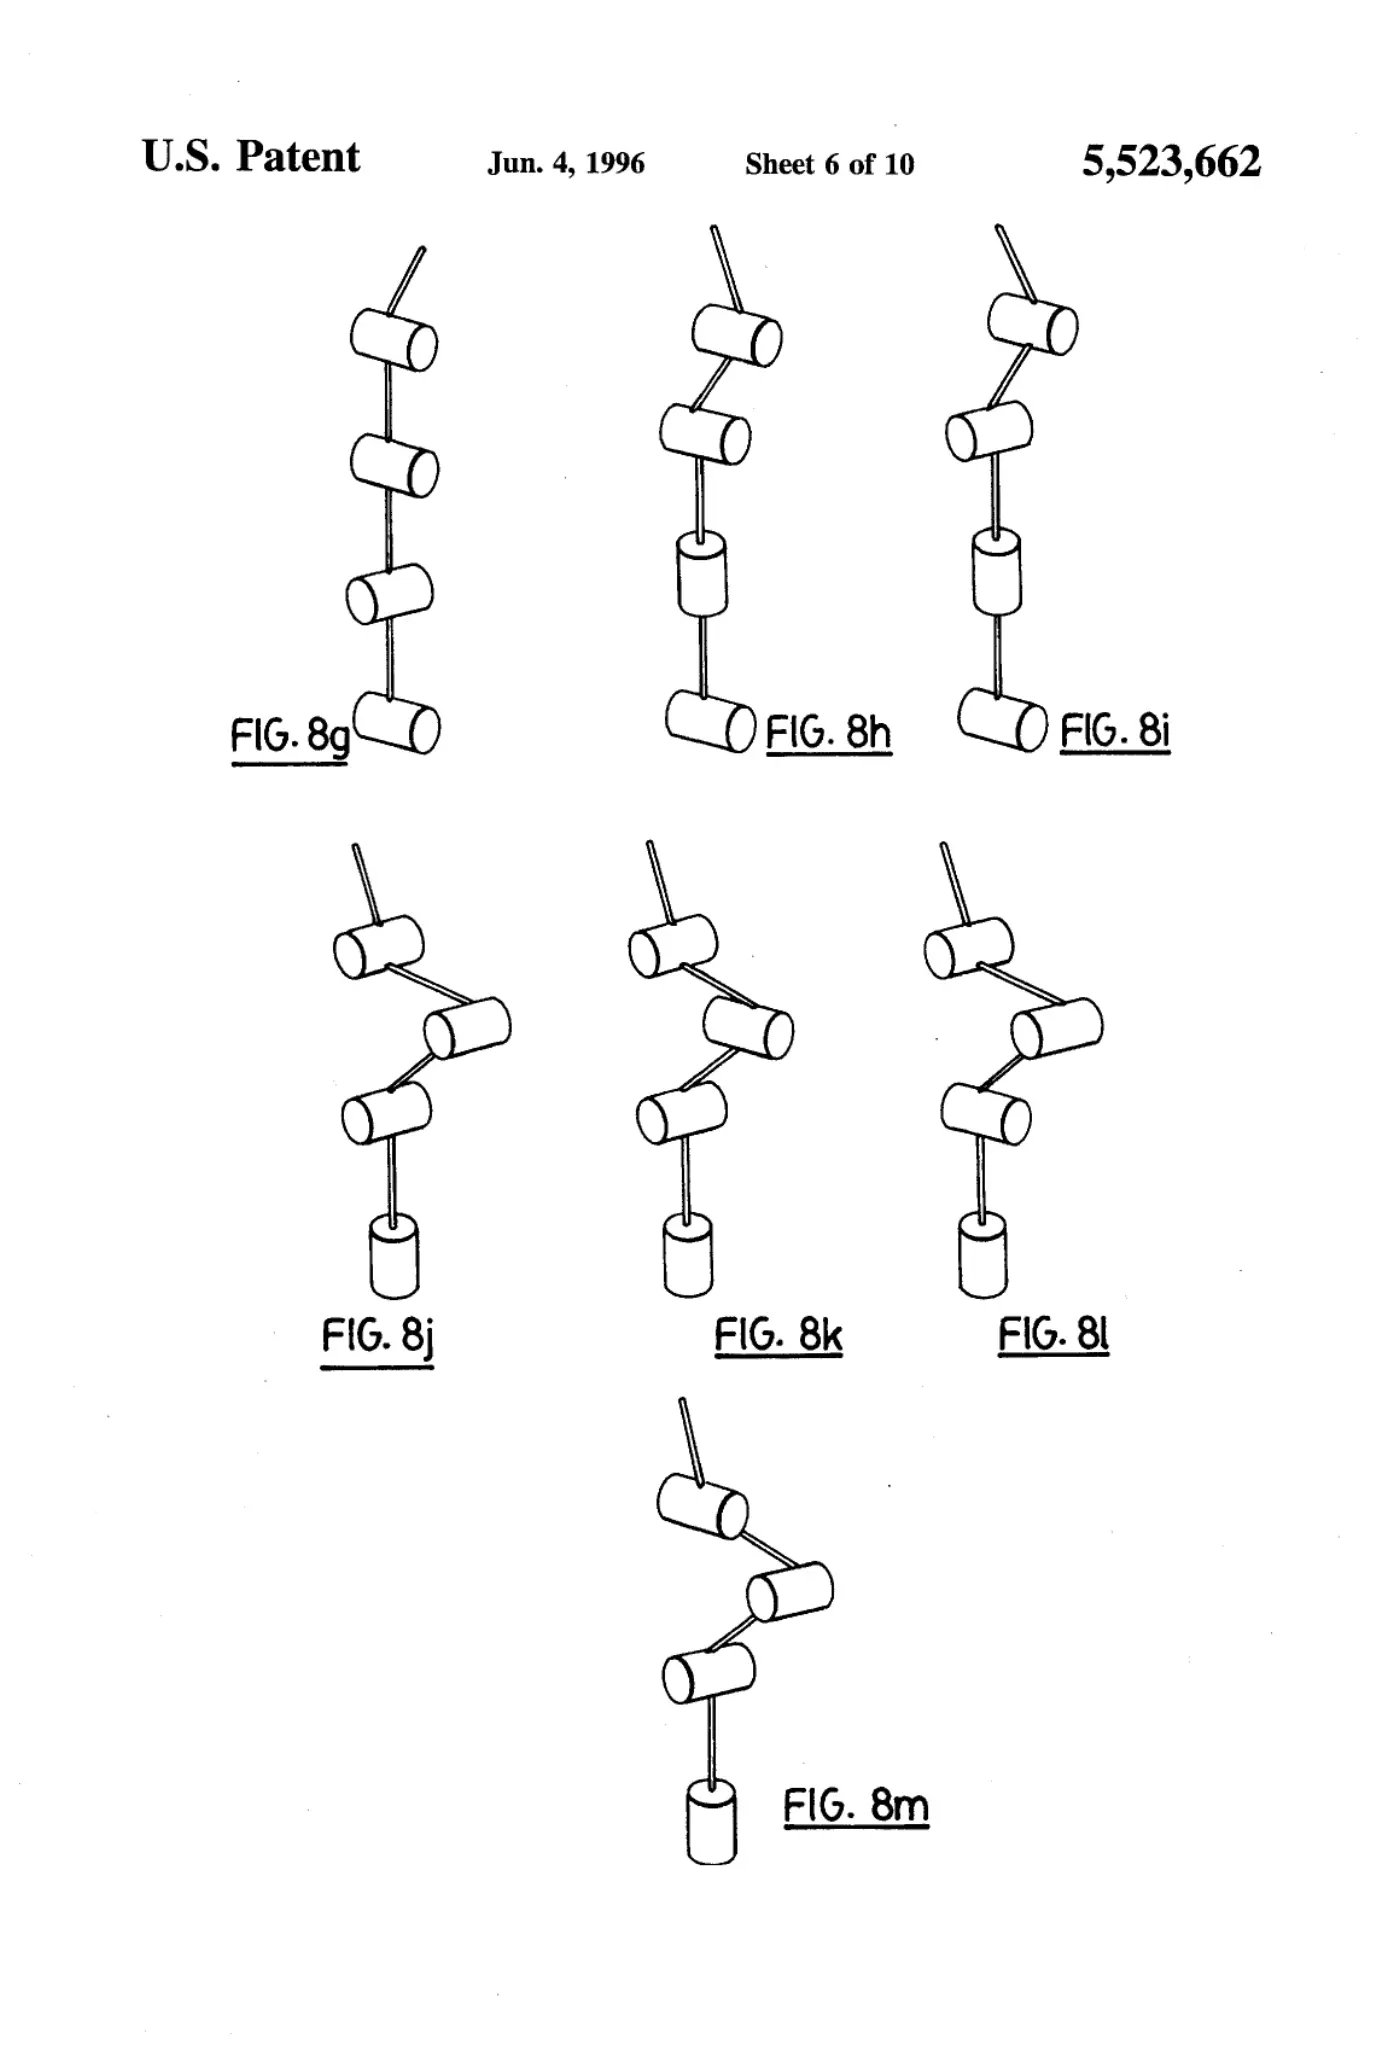
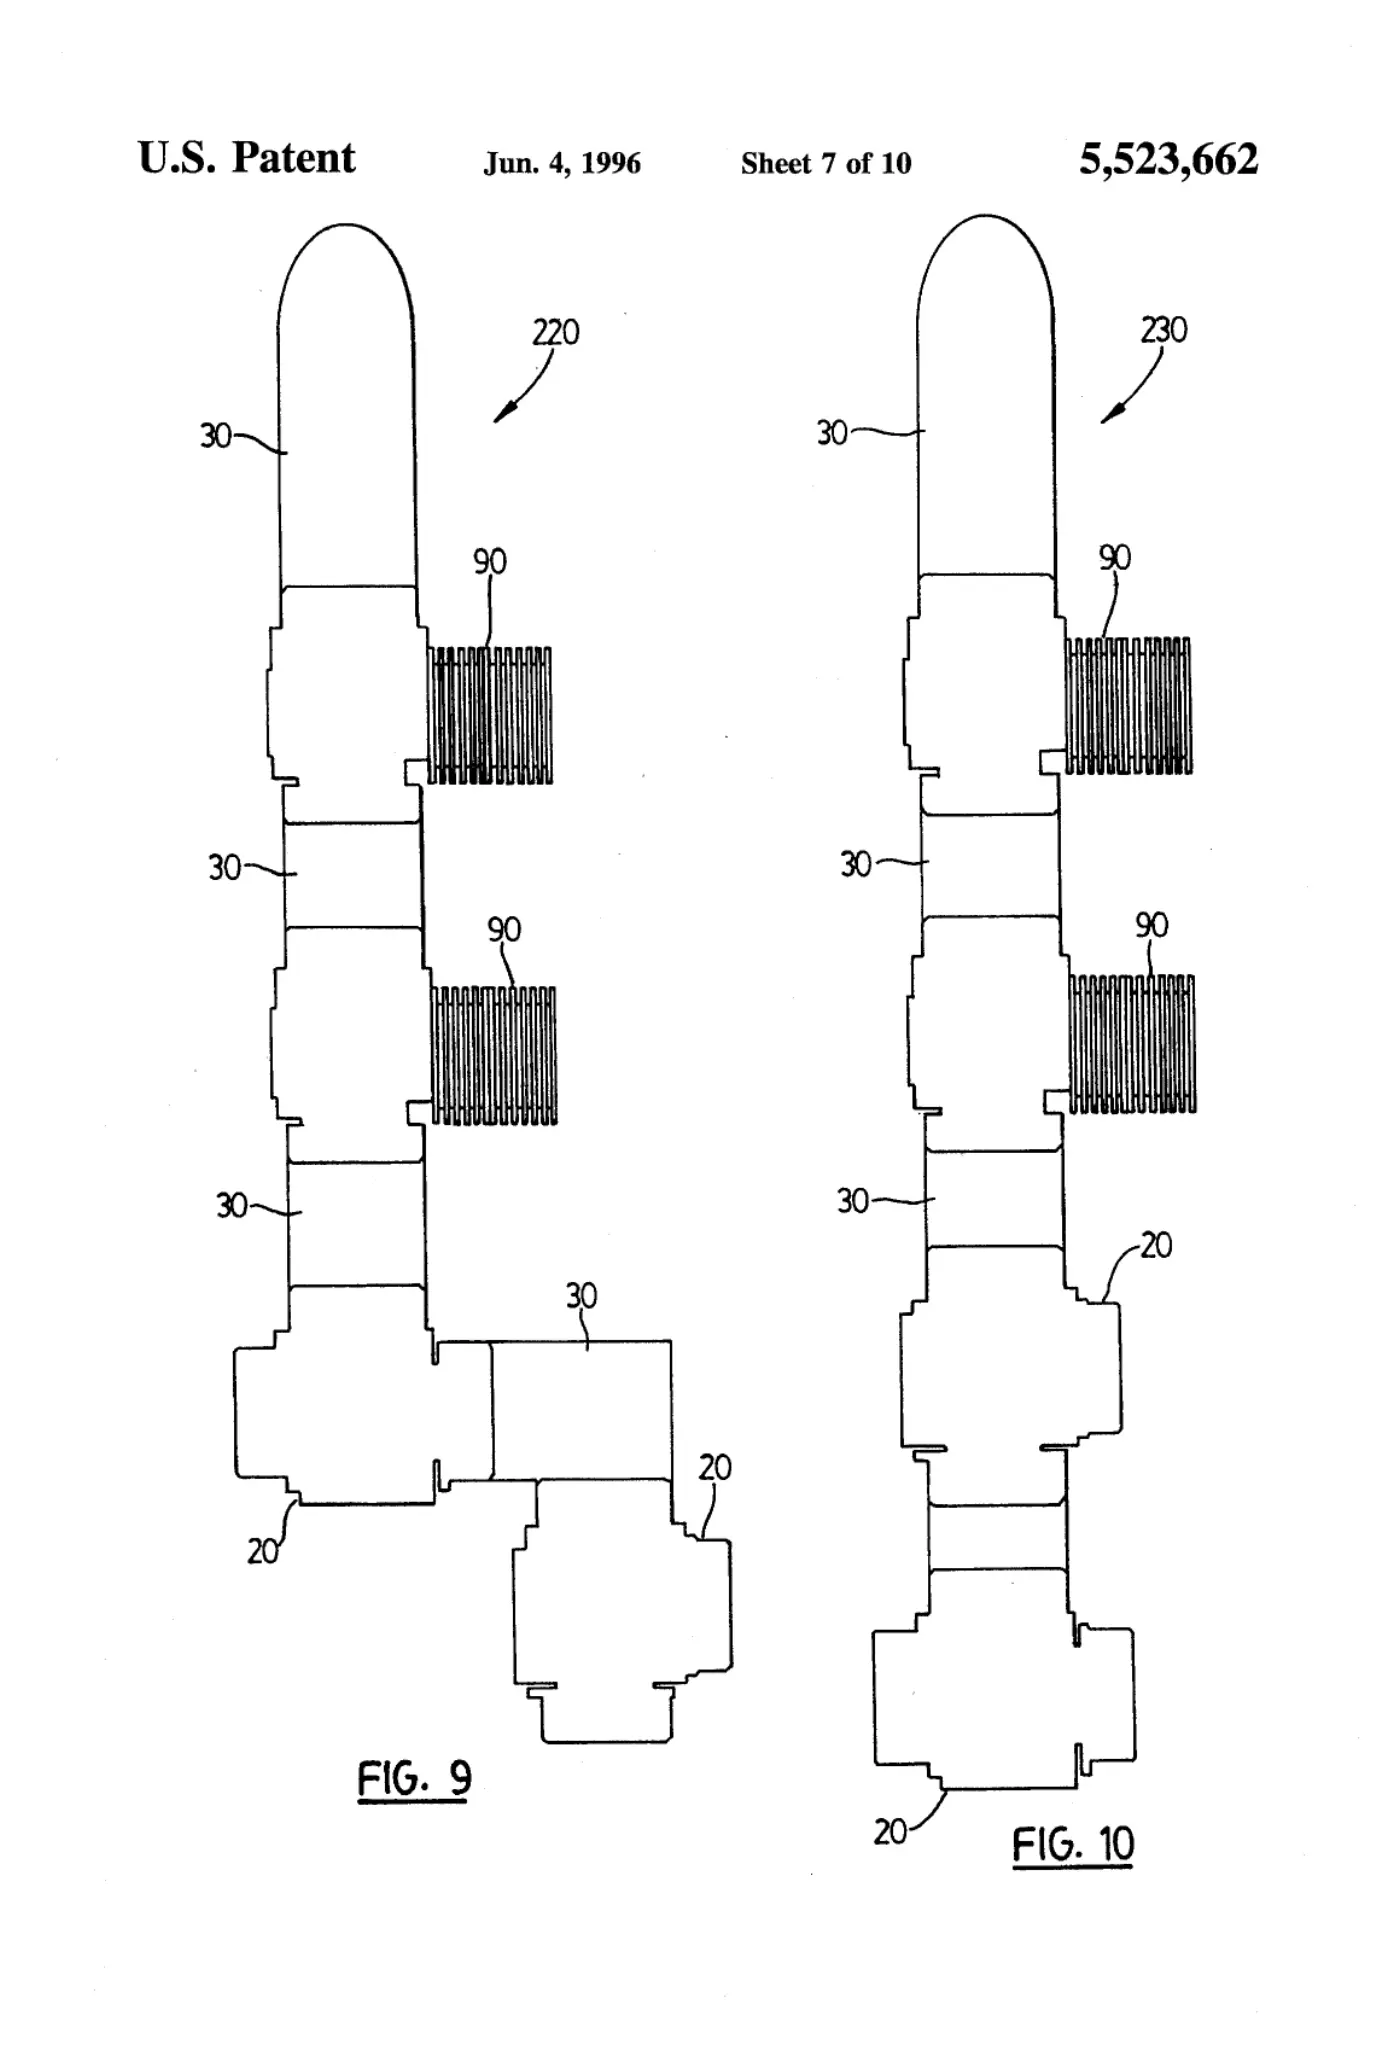
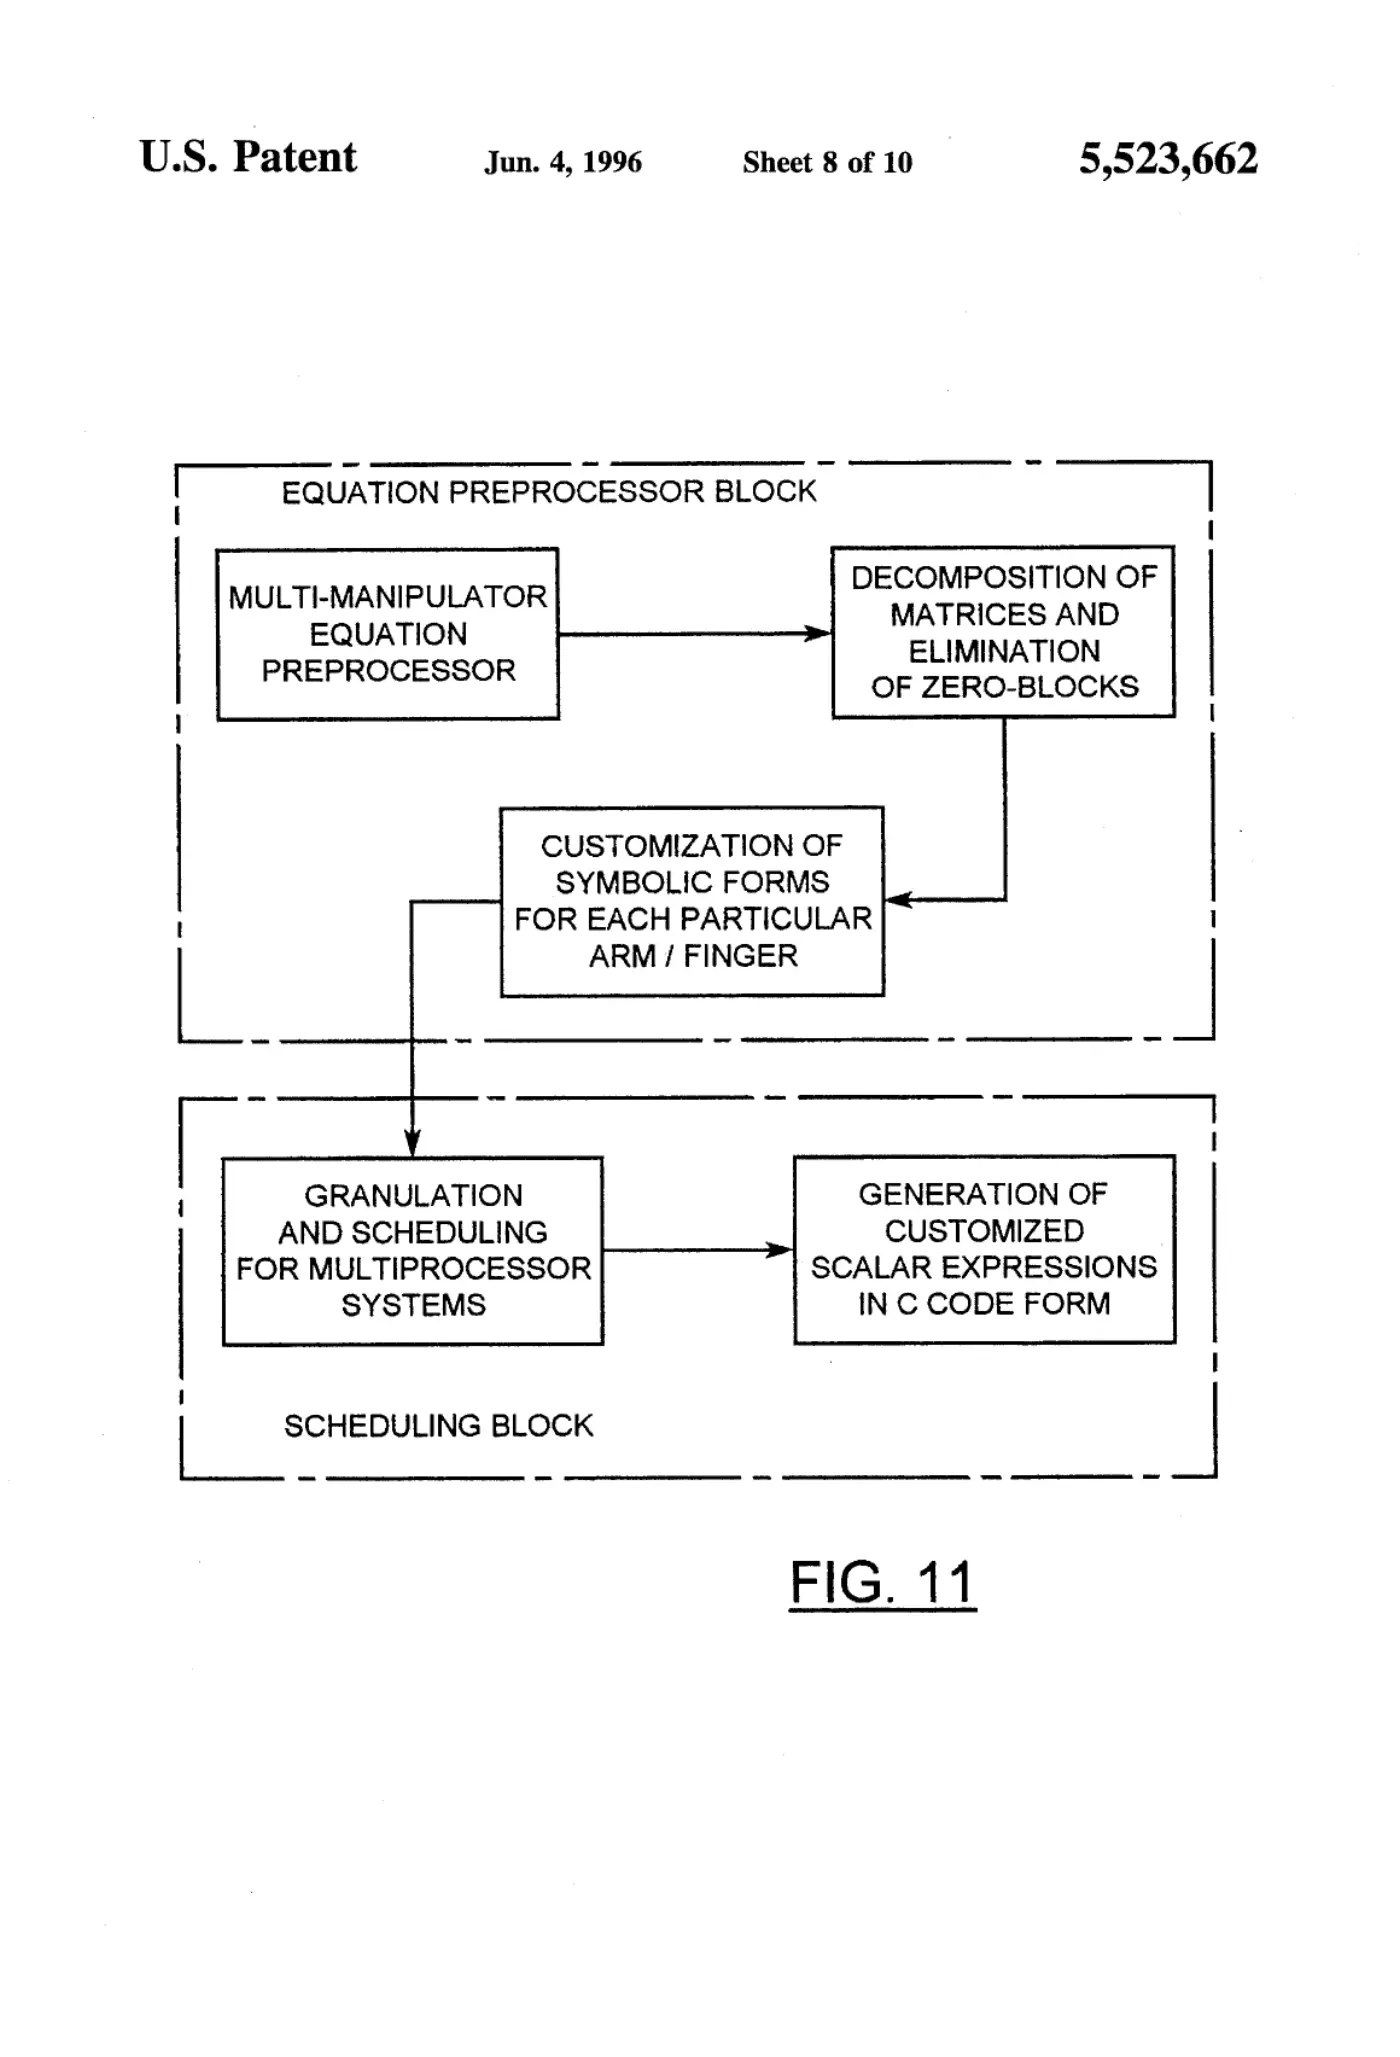
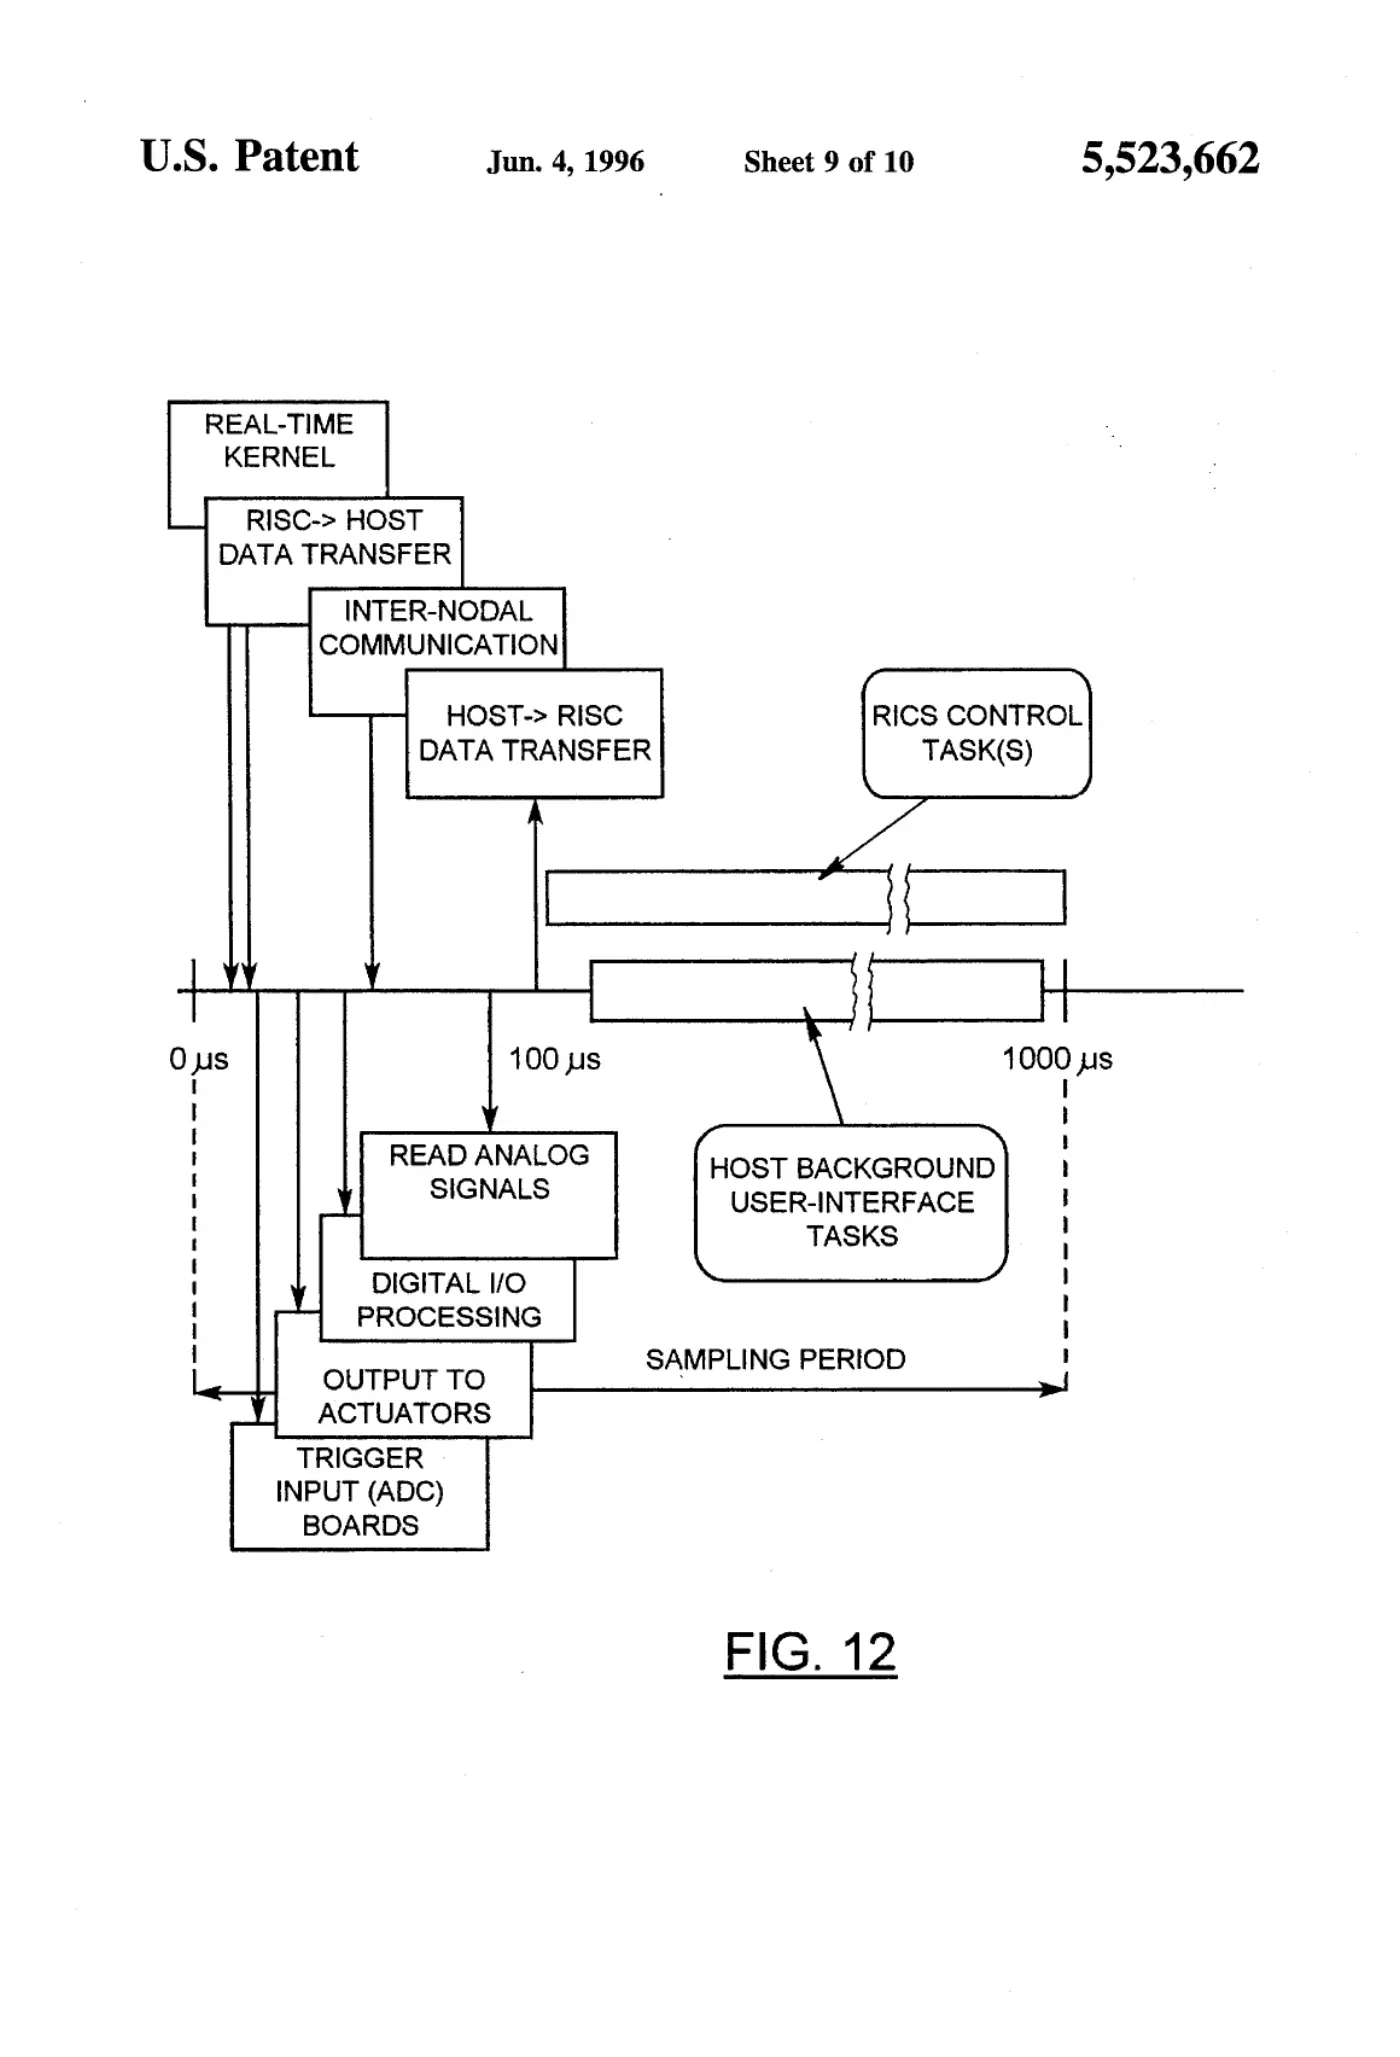
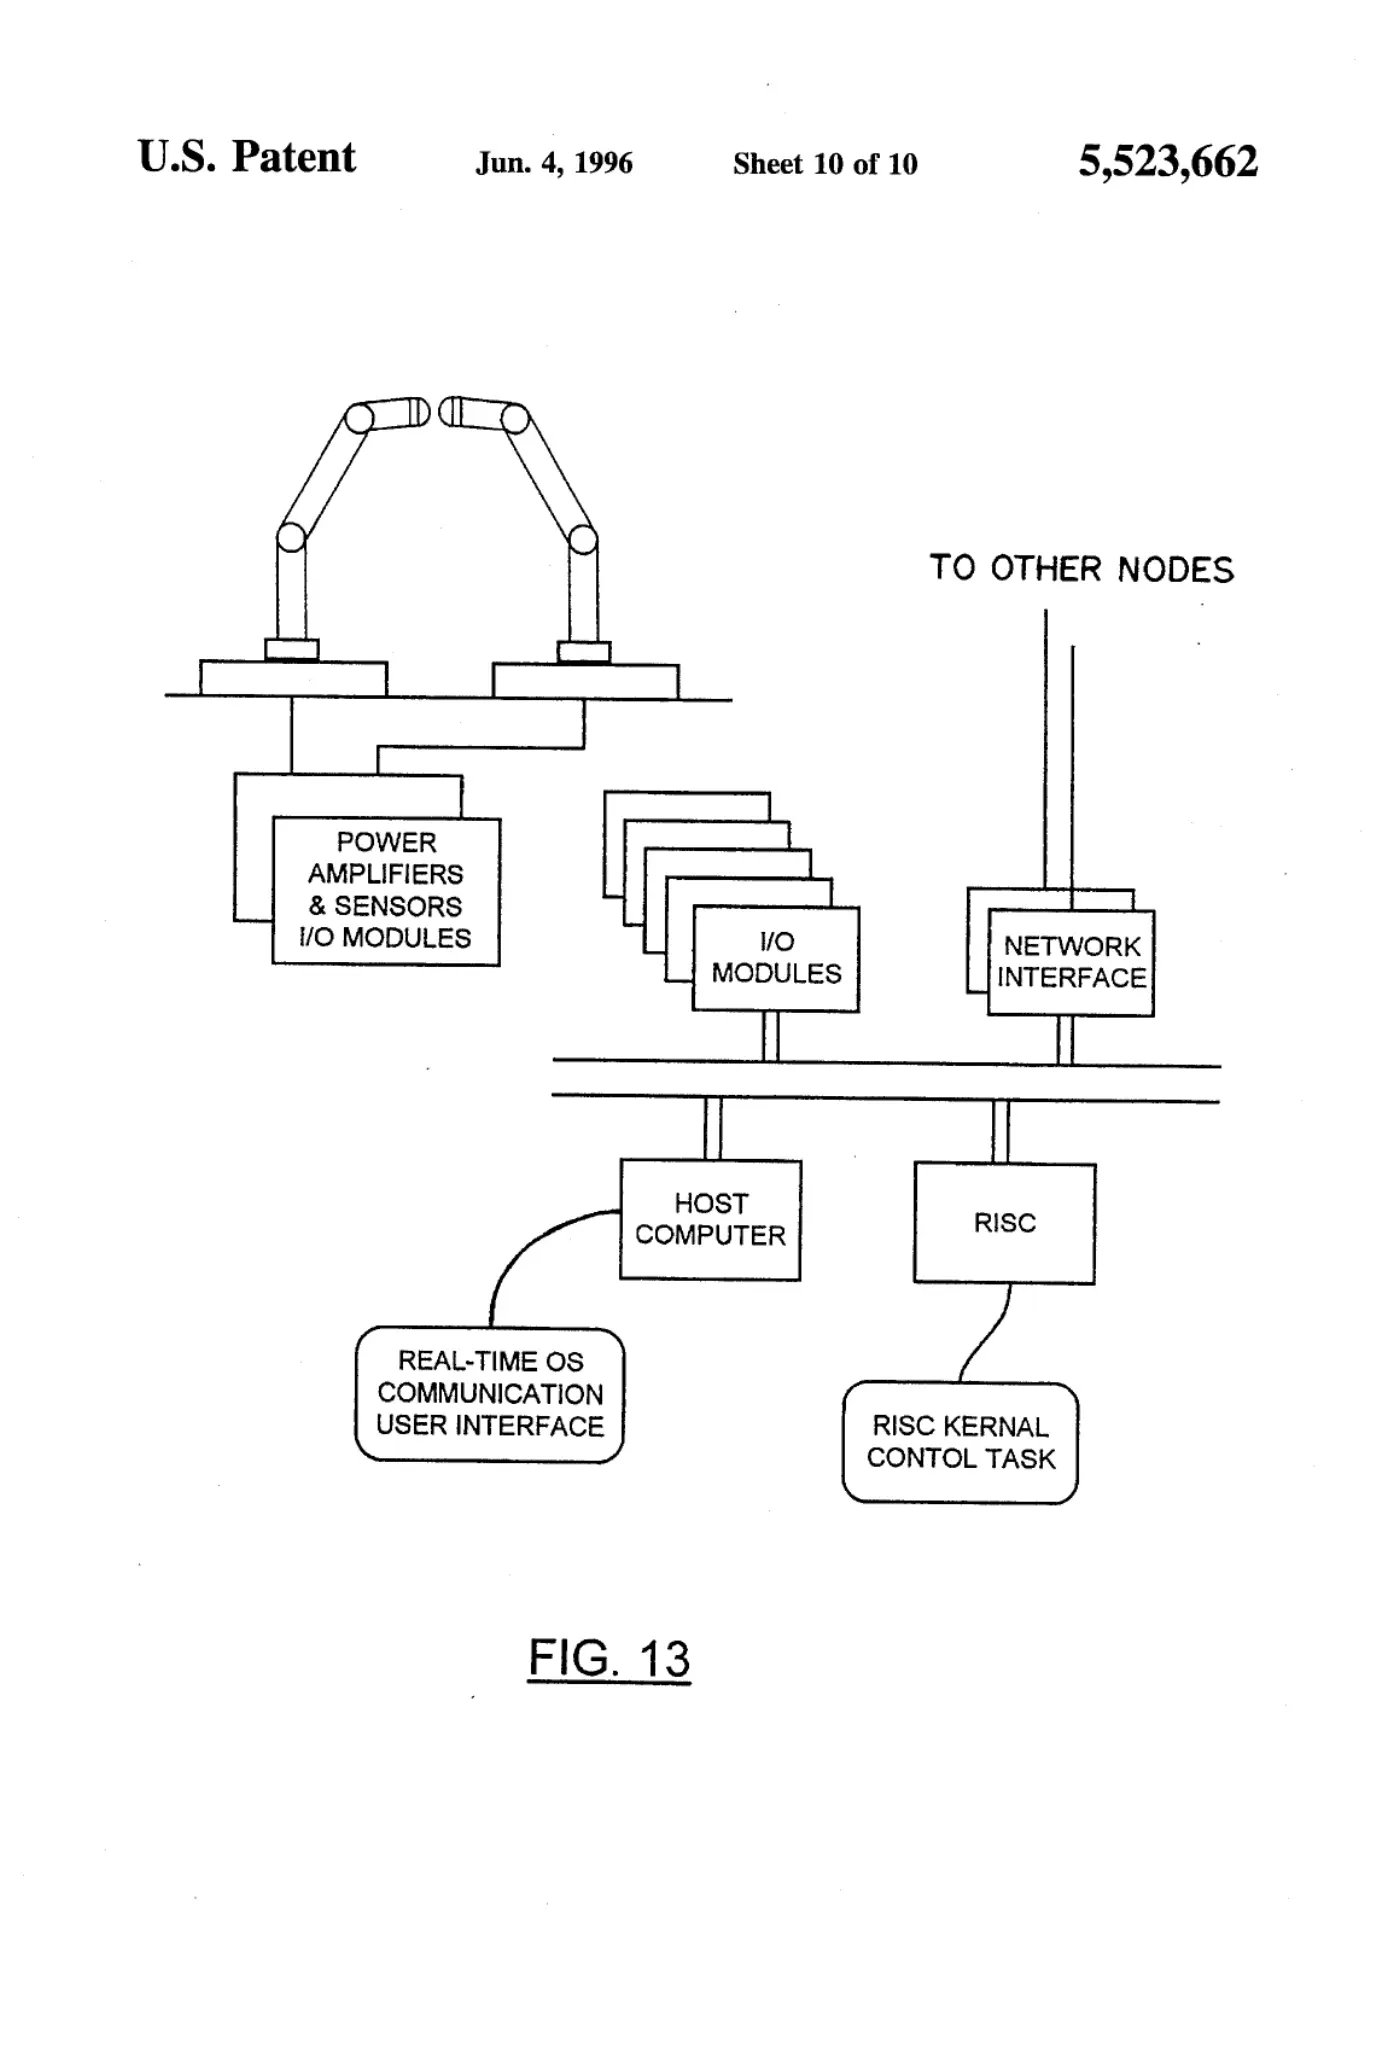
The subject invention provides a modular, expandable and reconfigurable robotic system. In one aspect of the invention there is provided a robot having at least two manipulators each having several compact rotary joints. The rotary joints have one input coupling and either one or two output couplings. Each joint is modular including a d.c. brushless motor coupled with a harmonic cup drive and includes position, velocity and torque sensors. Each manipulator may be disassembled and reassembled to assume a multitude of configurations. In another aspect of the invention there is provided an expandable and modular real-time computer control system for controlling the robot. The computer architecture achieves between 5 to 10 MFLOPS with reduced instruction set computing (RISC) processor nodes and a fast point-to-point communication network. Each node includes a host computer and parallel input/output (I/O) modules as well. The nodes are controlled by nearly zero-overhead real-time operating system (OS) kernels responsible for task scheduling, communication and user-interface. Each node is capable of controlling 8 joints at 1 kHz while executing over 1000 floating point operations per joint in each sampling interval.
Abstract
The subject invention provides a modular, expandable and reconfigurable robotic system. In one aspect of the invention there is provided a robot having at least two manipulators each having several compact rotary joints. The rotary joints have one input coupling and either one or two output couplings. Each joint is modular including a d.c. brushless motor coupled with a harmonic cup drive and includes position, velocity and torque sensors. Each manipulator may be disassembled and reassembled to assume a multitude of configurations. In another aspect of the invention there is provided an expandable and modular real-time computer control system for controlling the robot. The computer architecture achieves between 5 to 10 MFLOPS with reduced instruction set computing (RISC) processor nodes and a fast point-to-point communication network. Each node includes a host computer and parallel input/output (I/O) modules as well. The nodes are controlled by nearly zero-overhead real-time operating system (OS) kernels responsible for task scheduling, communication and user-interface. Each node is capable of controlling 8 joints at 1 kHz while executing over 1000 floating point operations per joint in each sampling interval.
1. Drawings
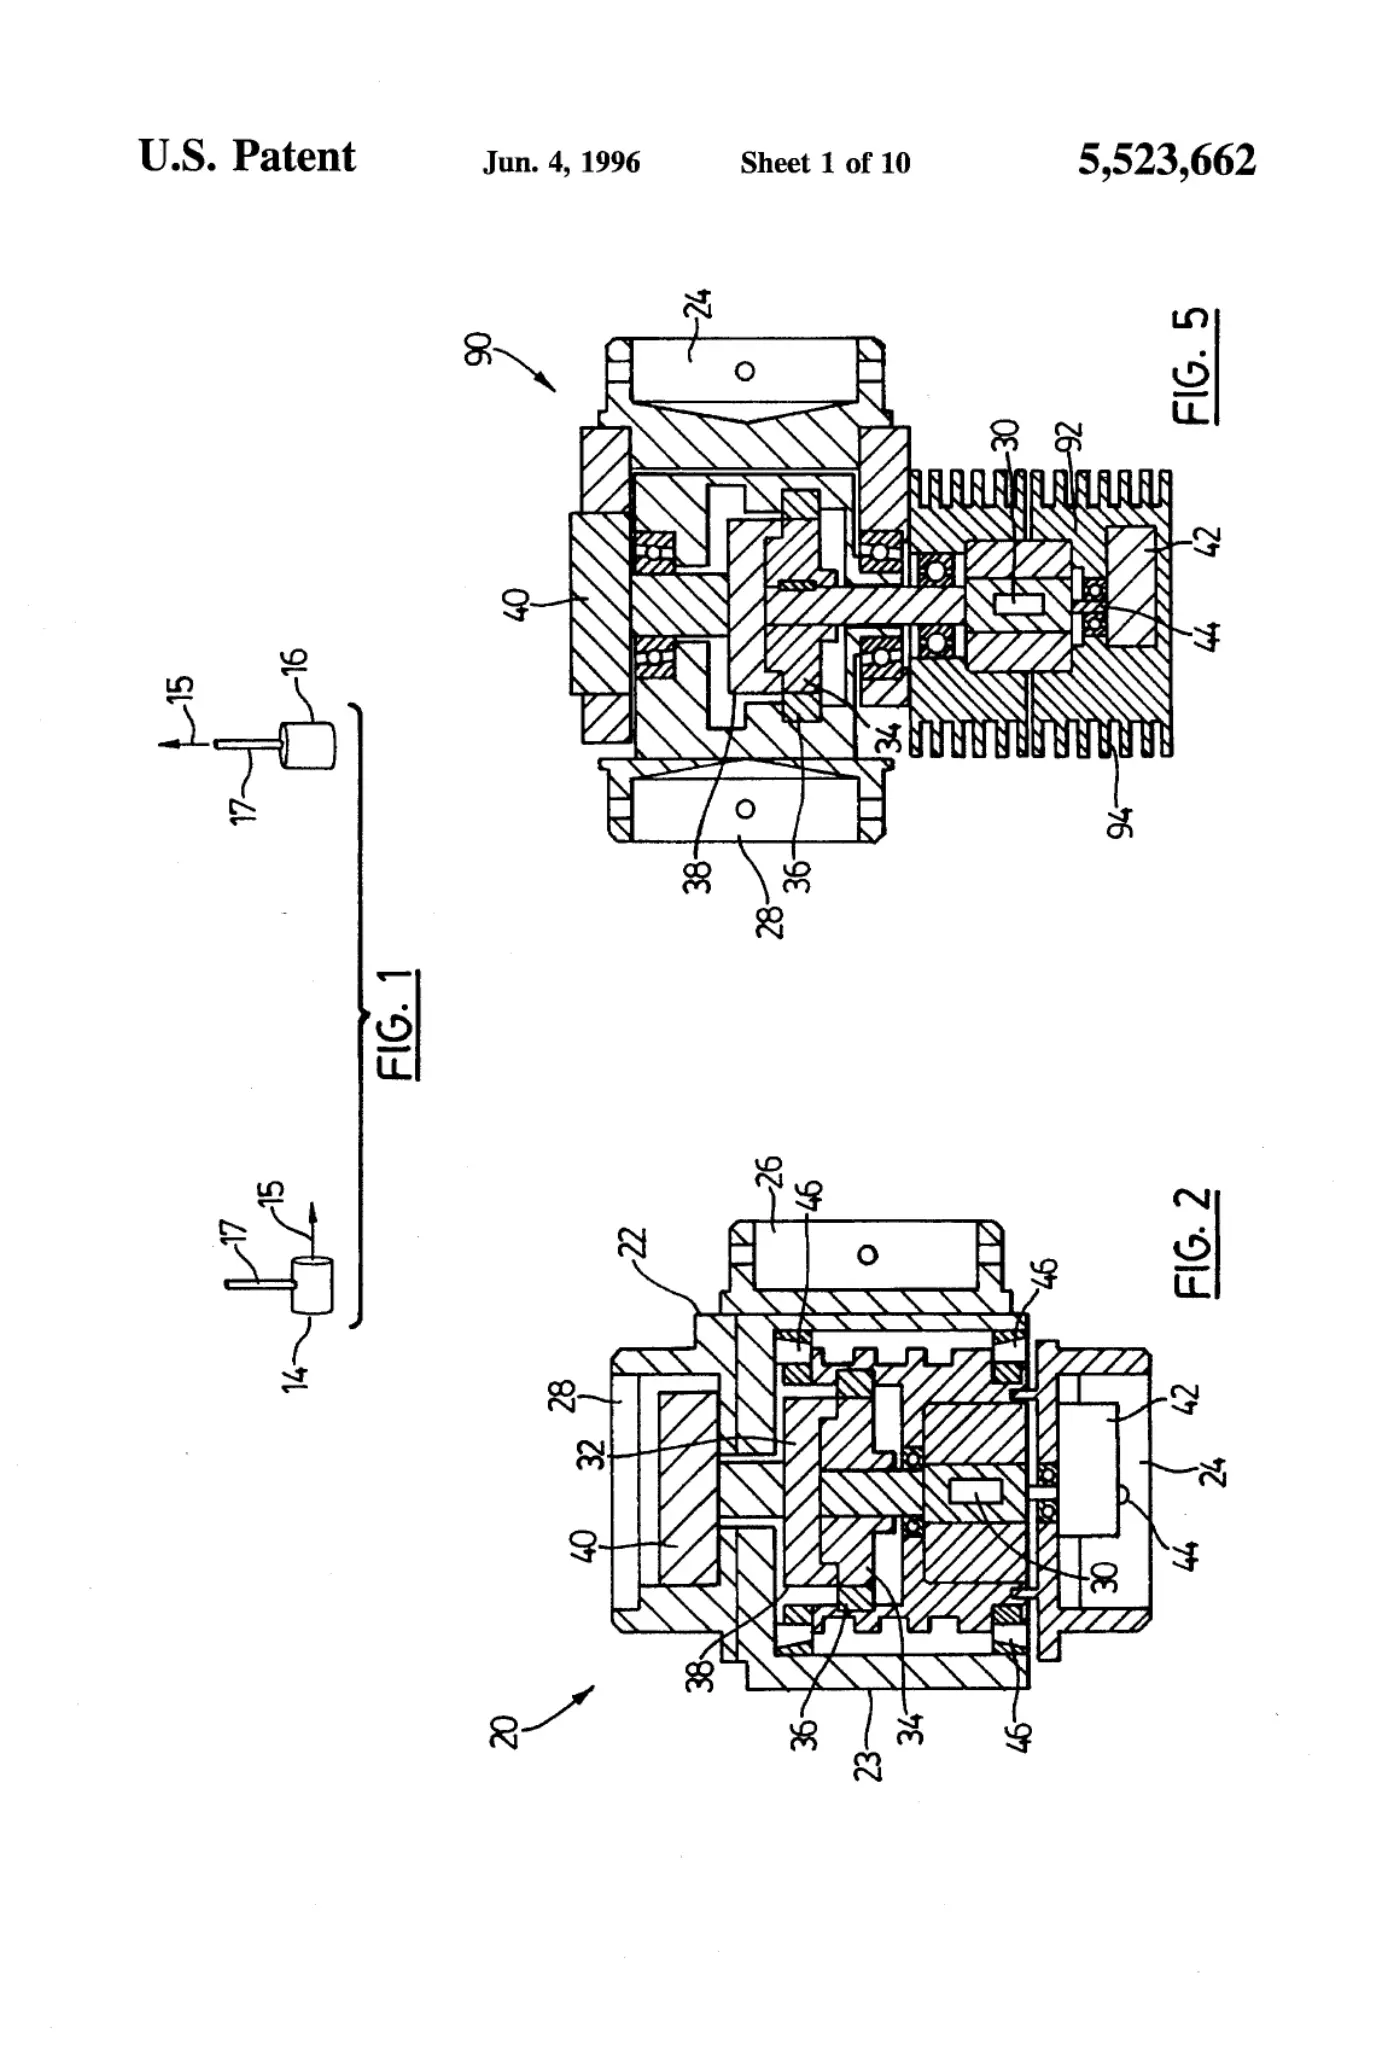
[0001]Sheet 1.
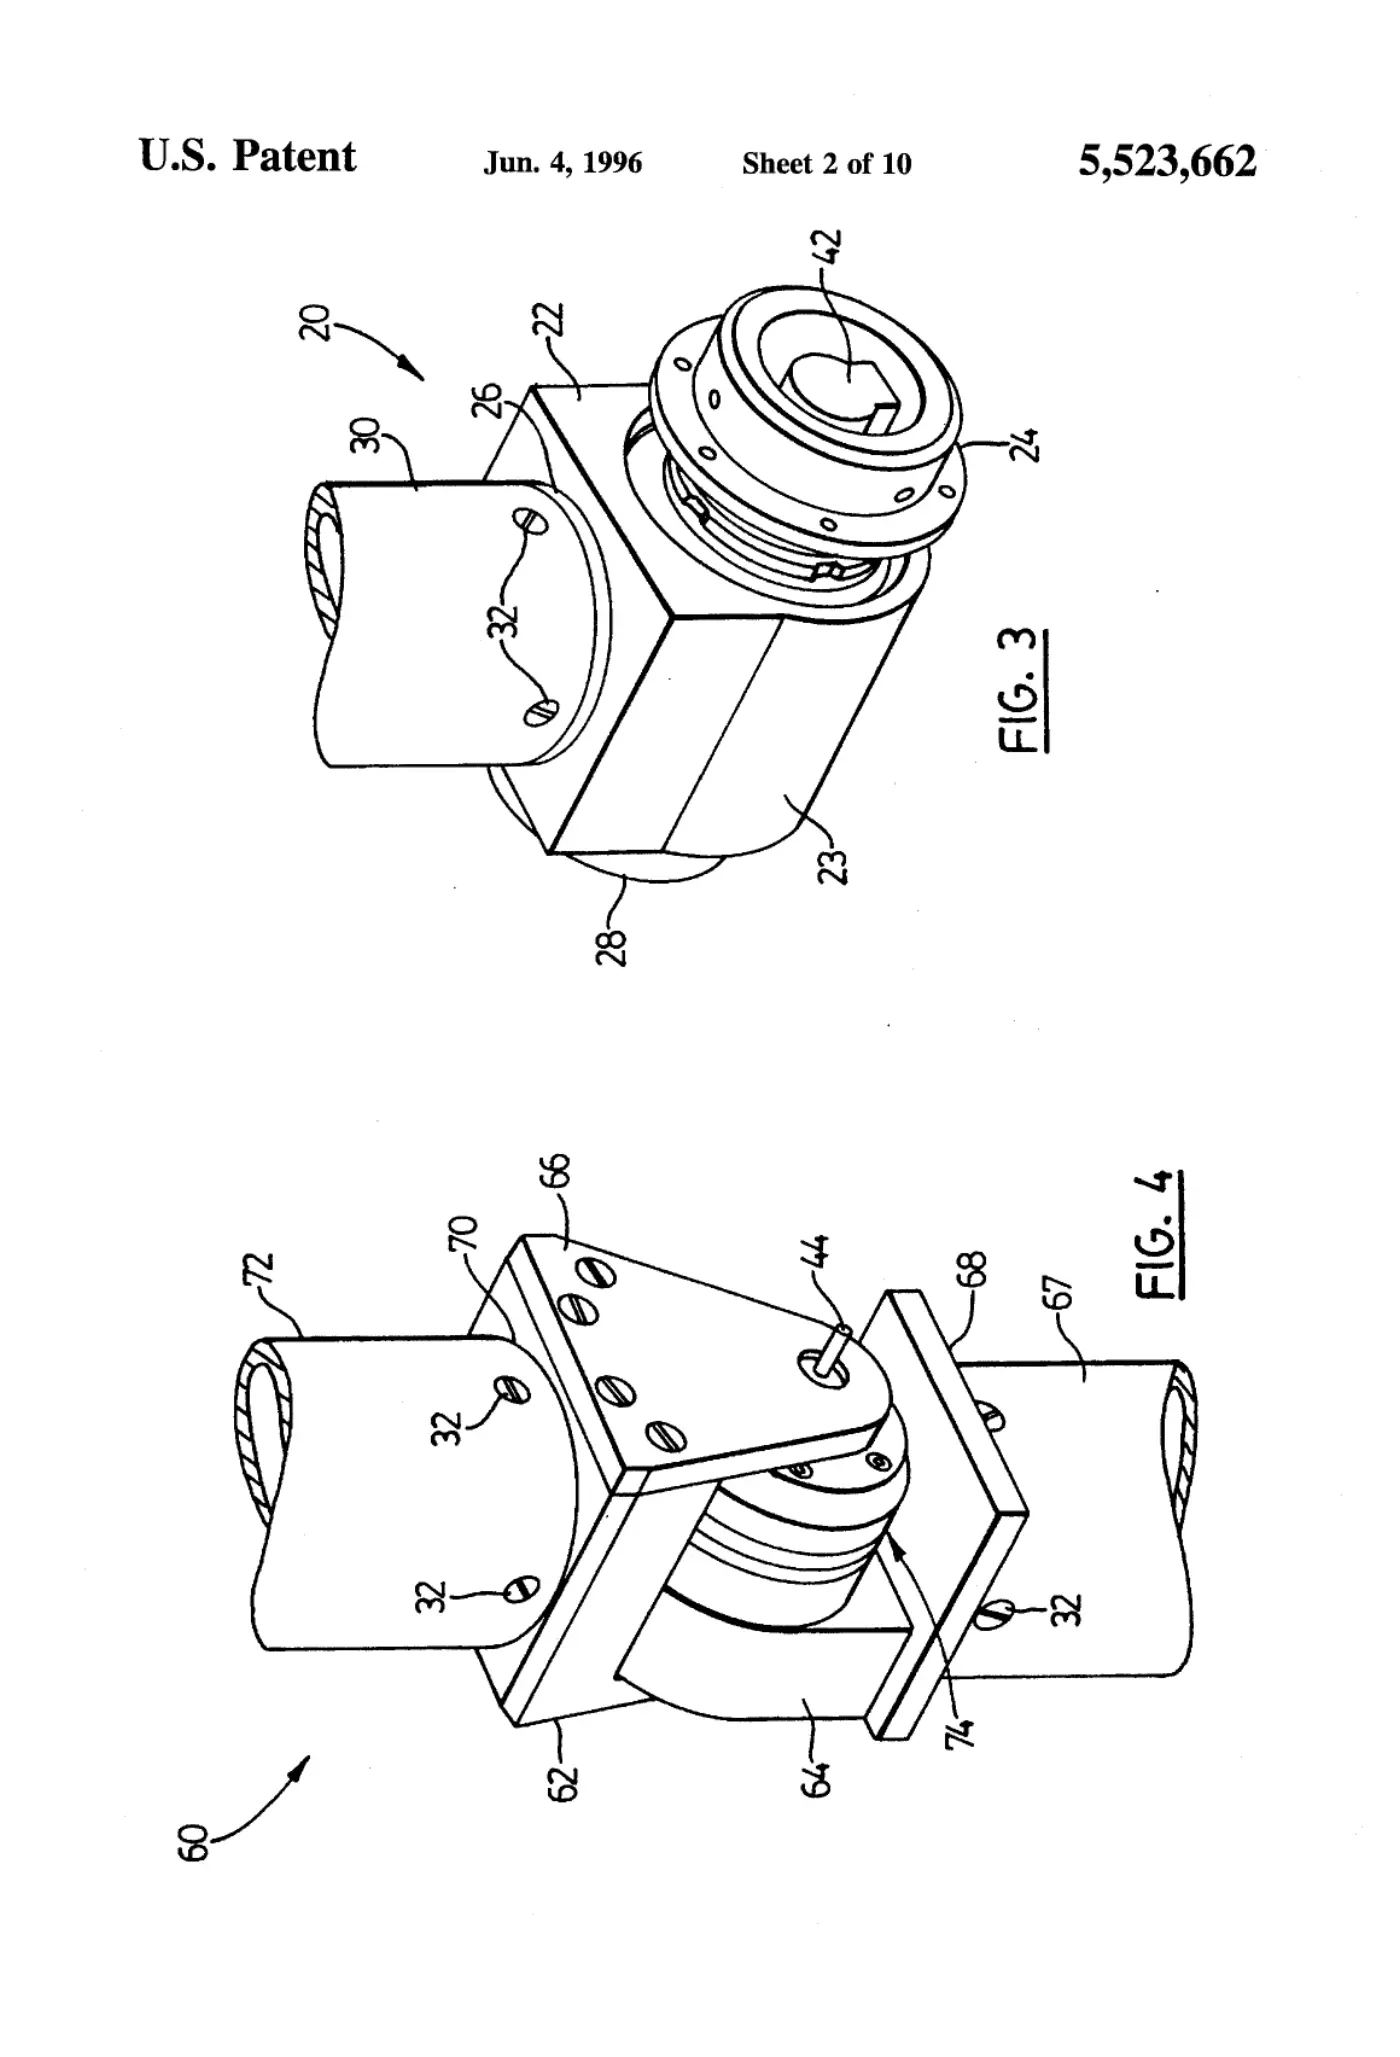
[0002]Sheet 2.
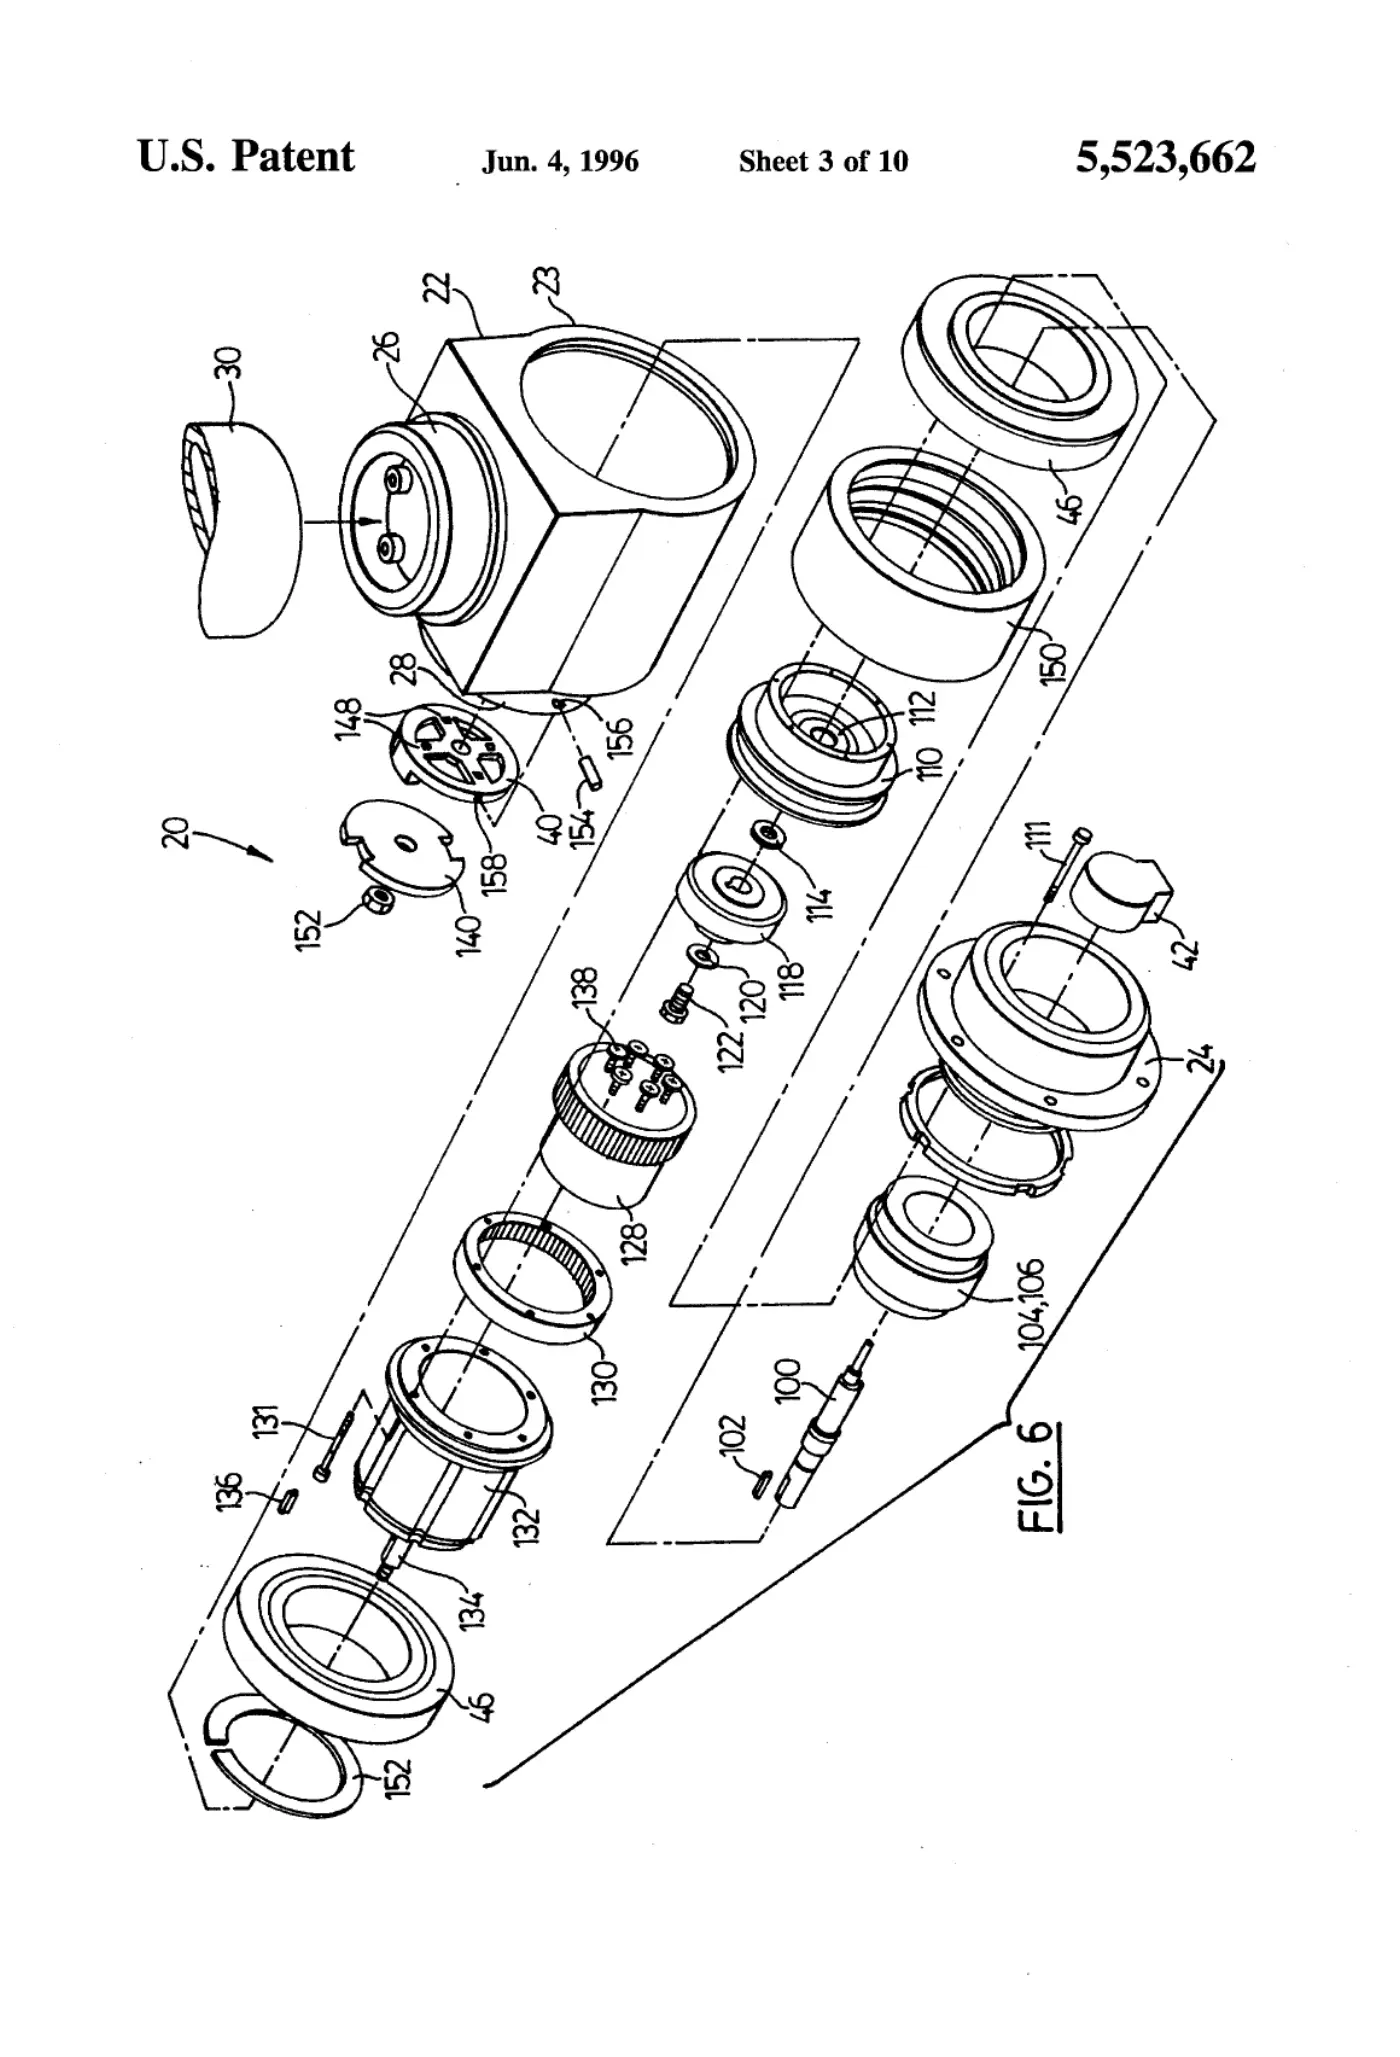
[0003]Sheet 3.
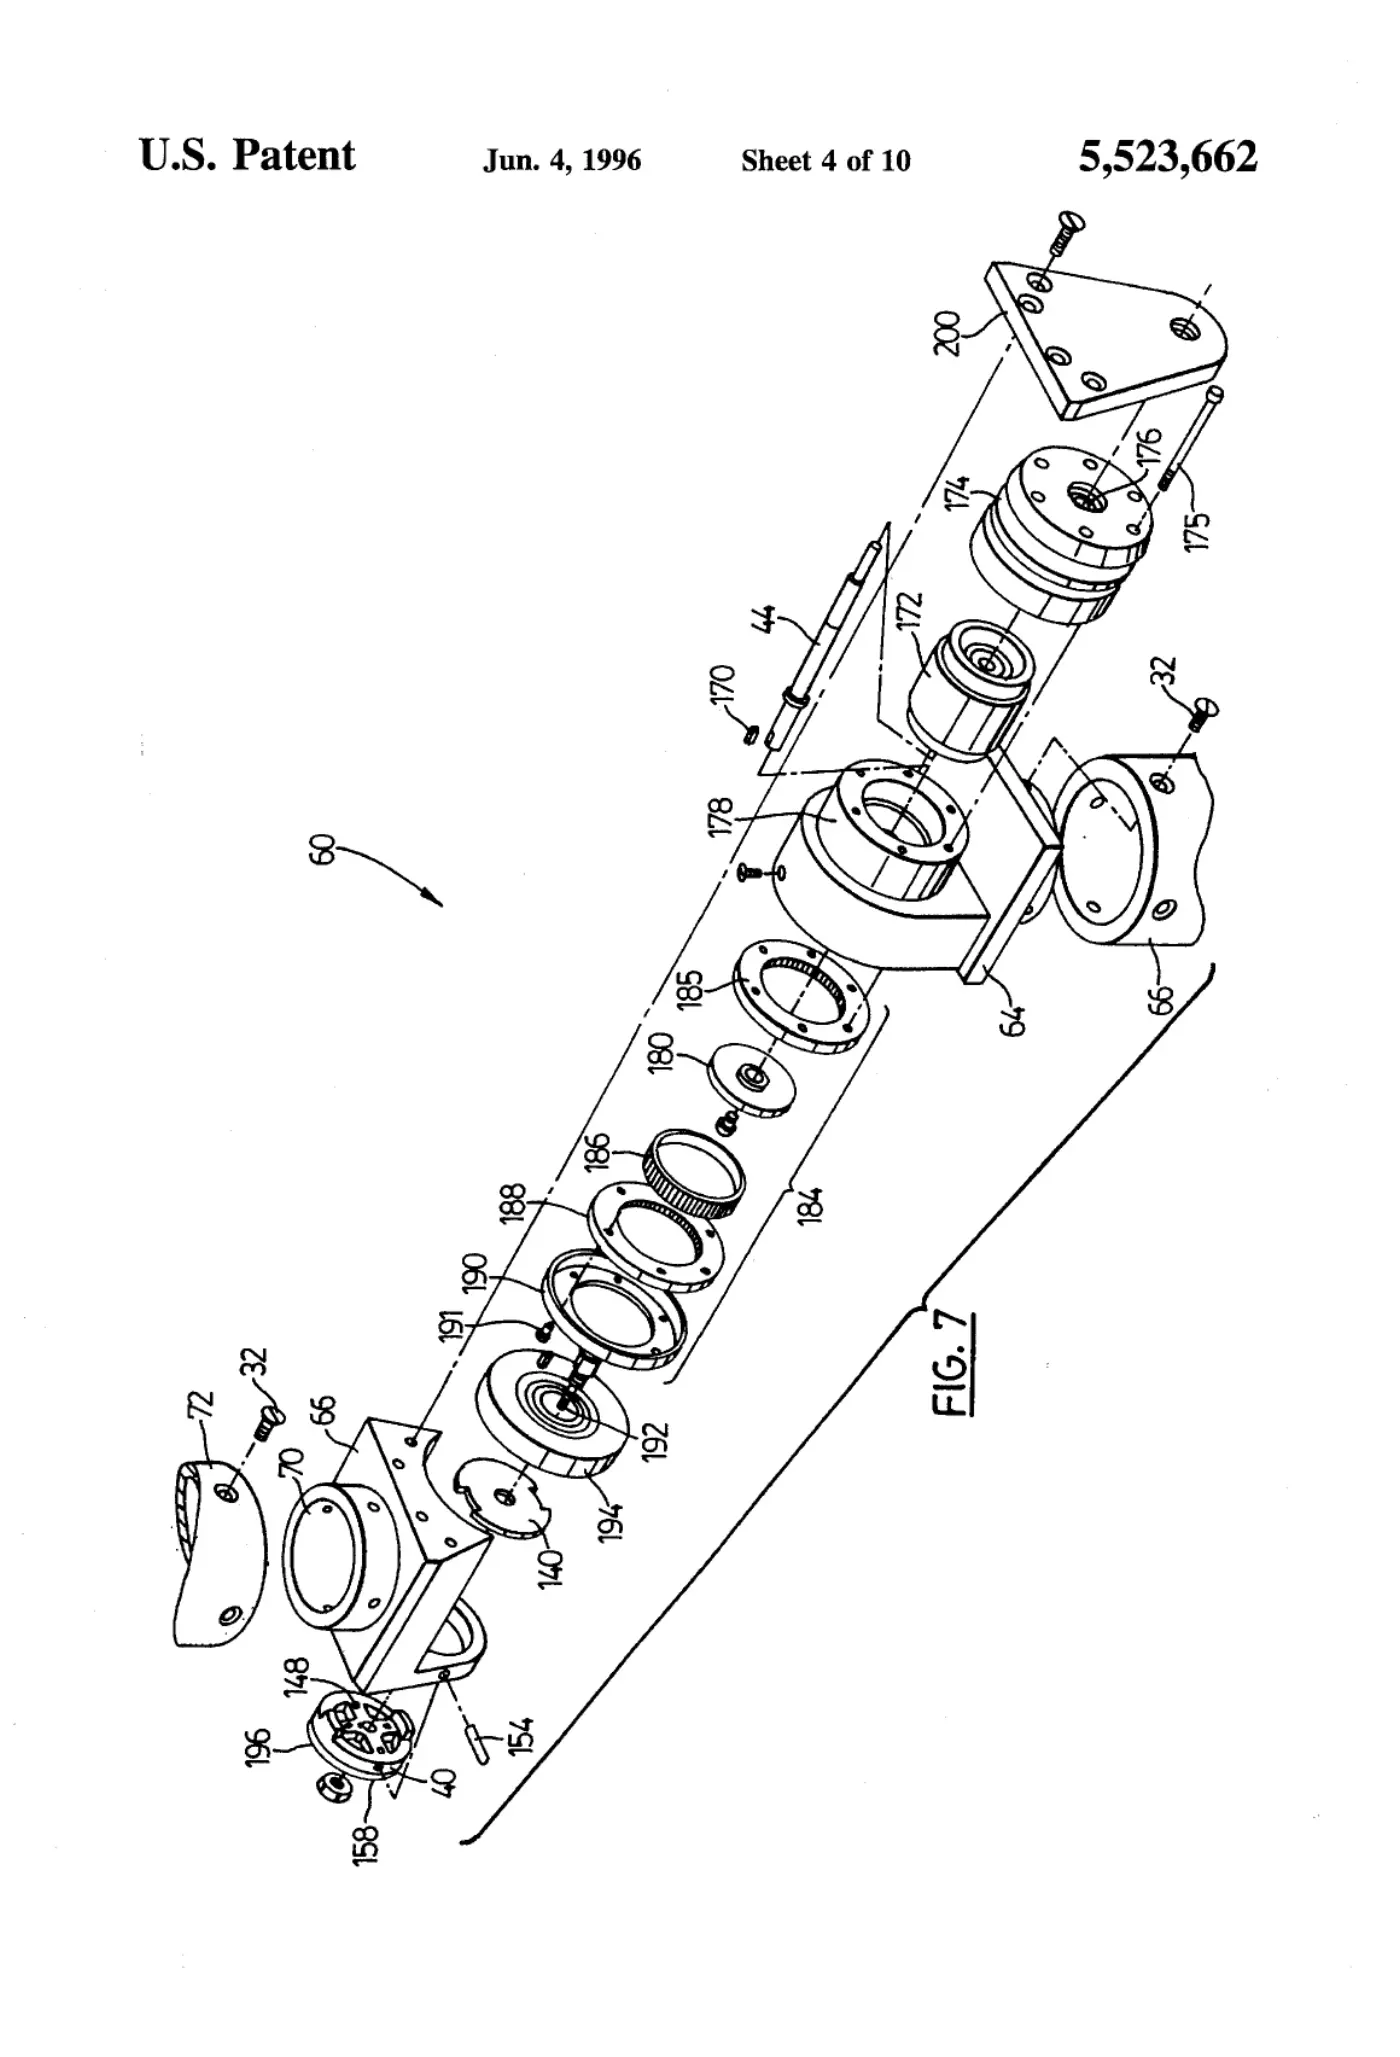
[0004]Sheet 4.
[0005]Sheet 5.
[0006]Sheet 6.
[0007]Sheet 7.
[0008]Sheet 8.
[0009]Sheet 9.
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003283, “Modular, expandable and reconfigurable robot,” published September 15, 2026 at 20:02:22 UTC, https://opentechnical.org/p/OT-2026-000003283.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.