OT-2026-000003288
Integrated group of excavator control assemblies
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003288
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- STRICKLAND WILLIAM A
- Original source
- US-5497568-A, the United States Patent and Trademark Office, 12 March 1996
- Document SHA-256
- d6162158791ea01abf339efdaa4dd72fe111943823dc29dda6ecaa1983f733b1
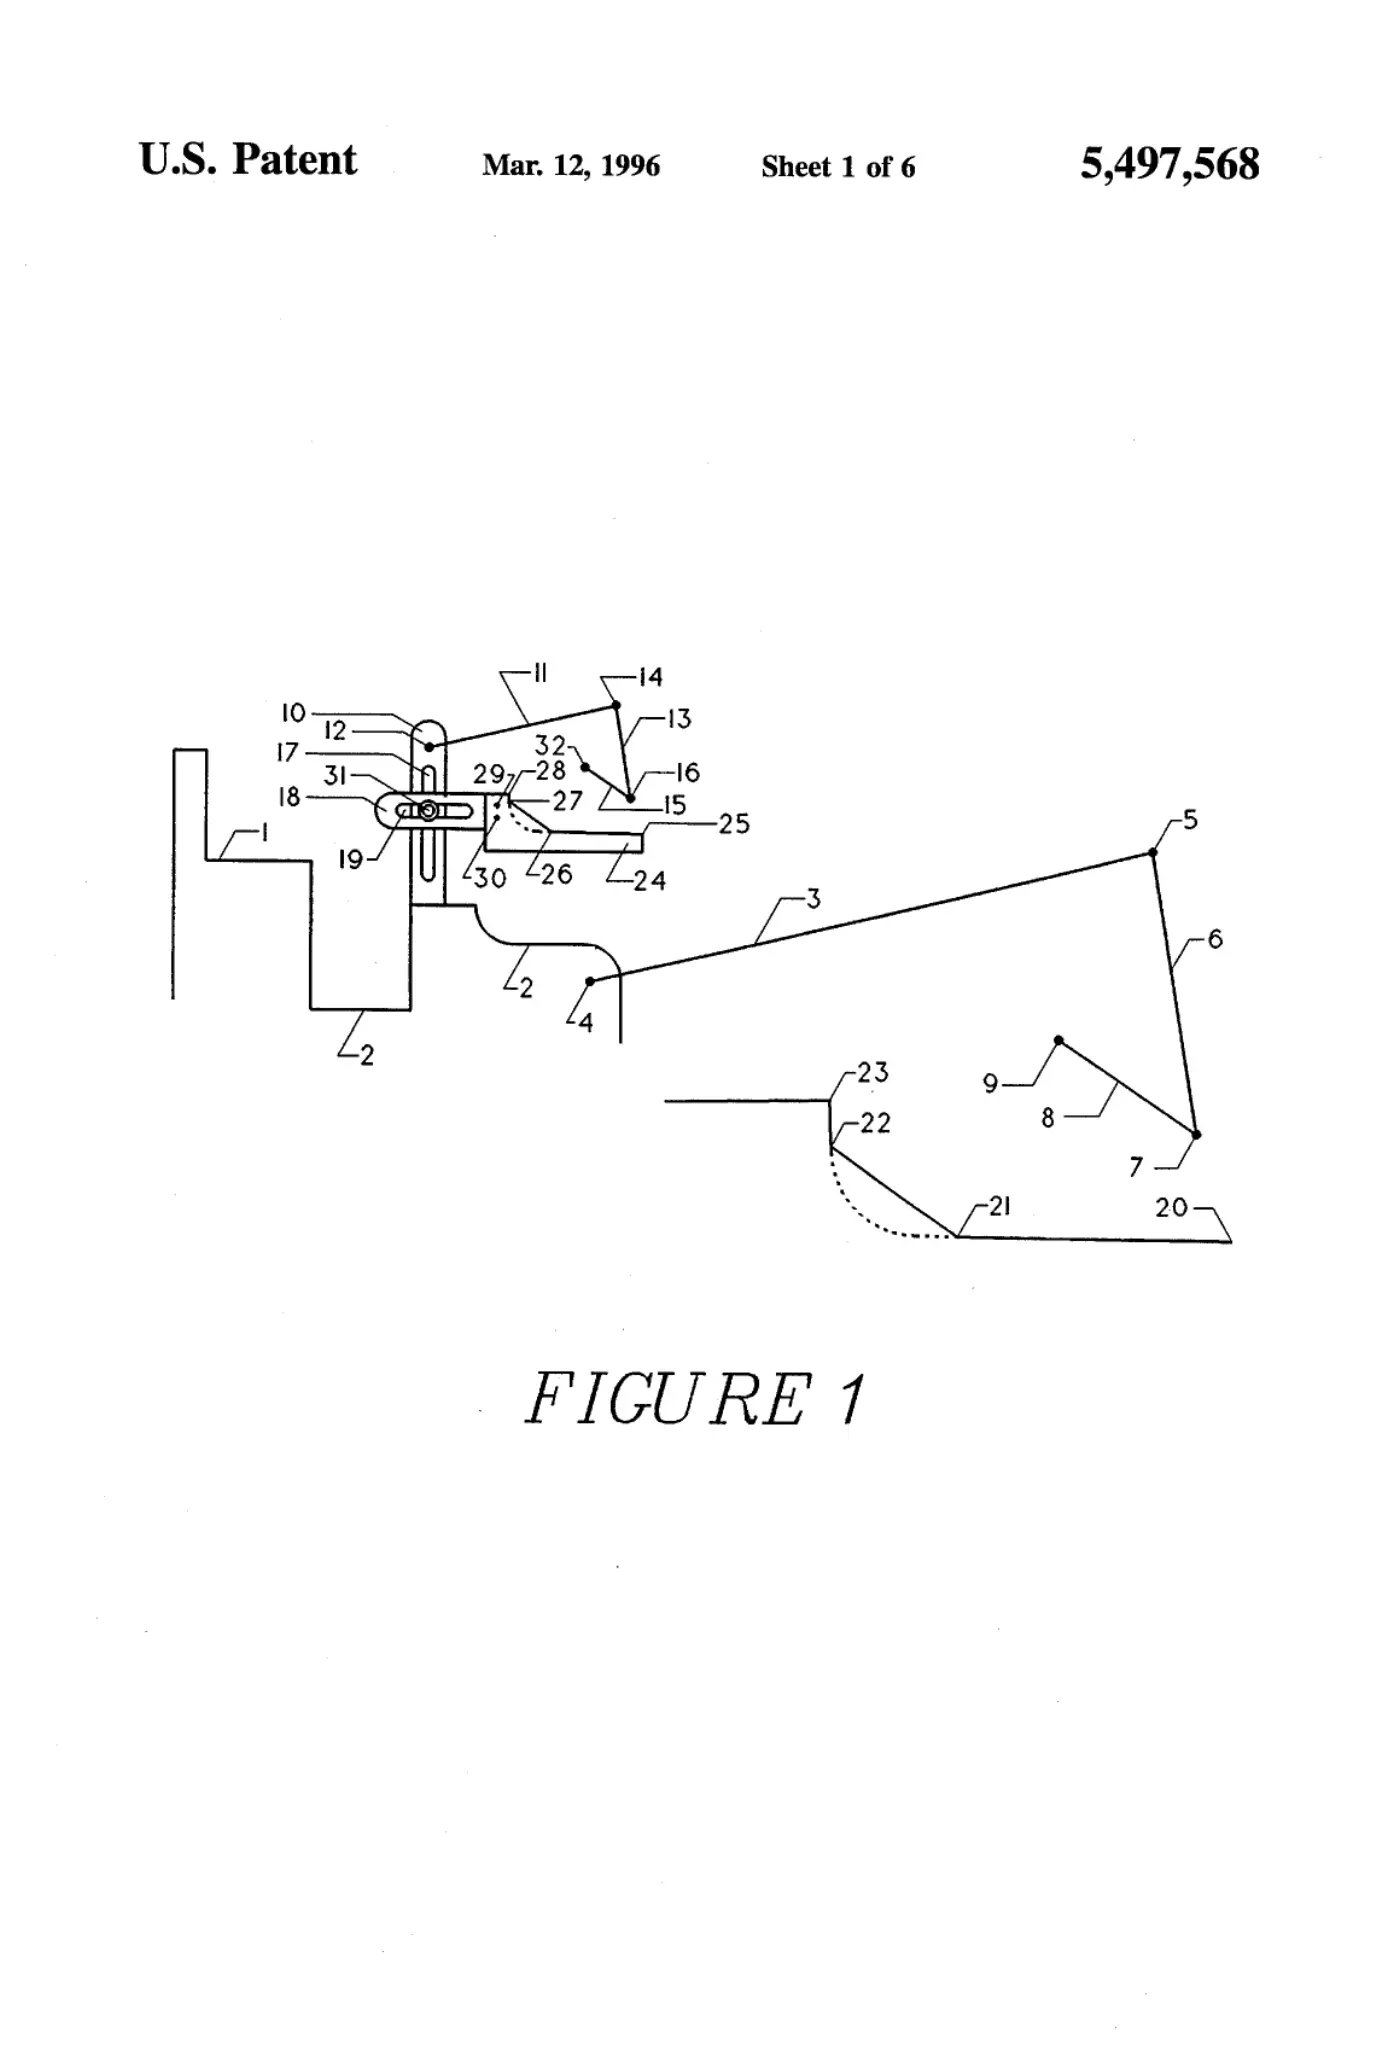
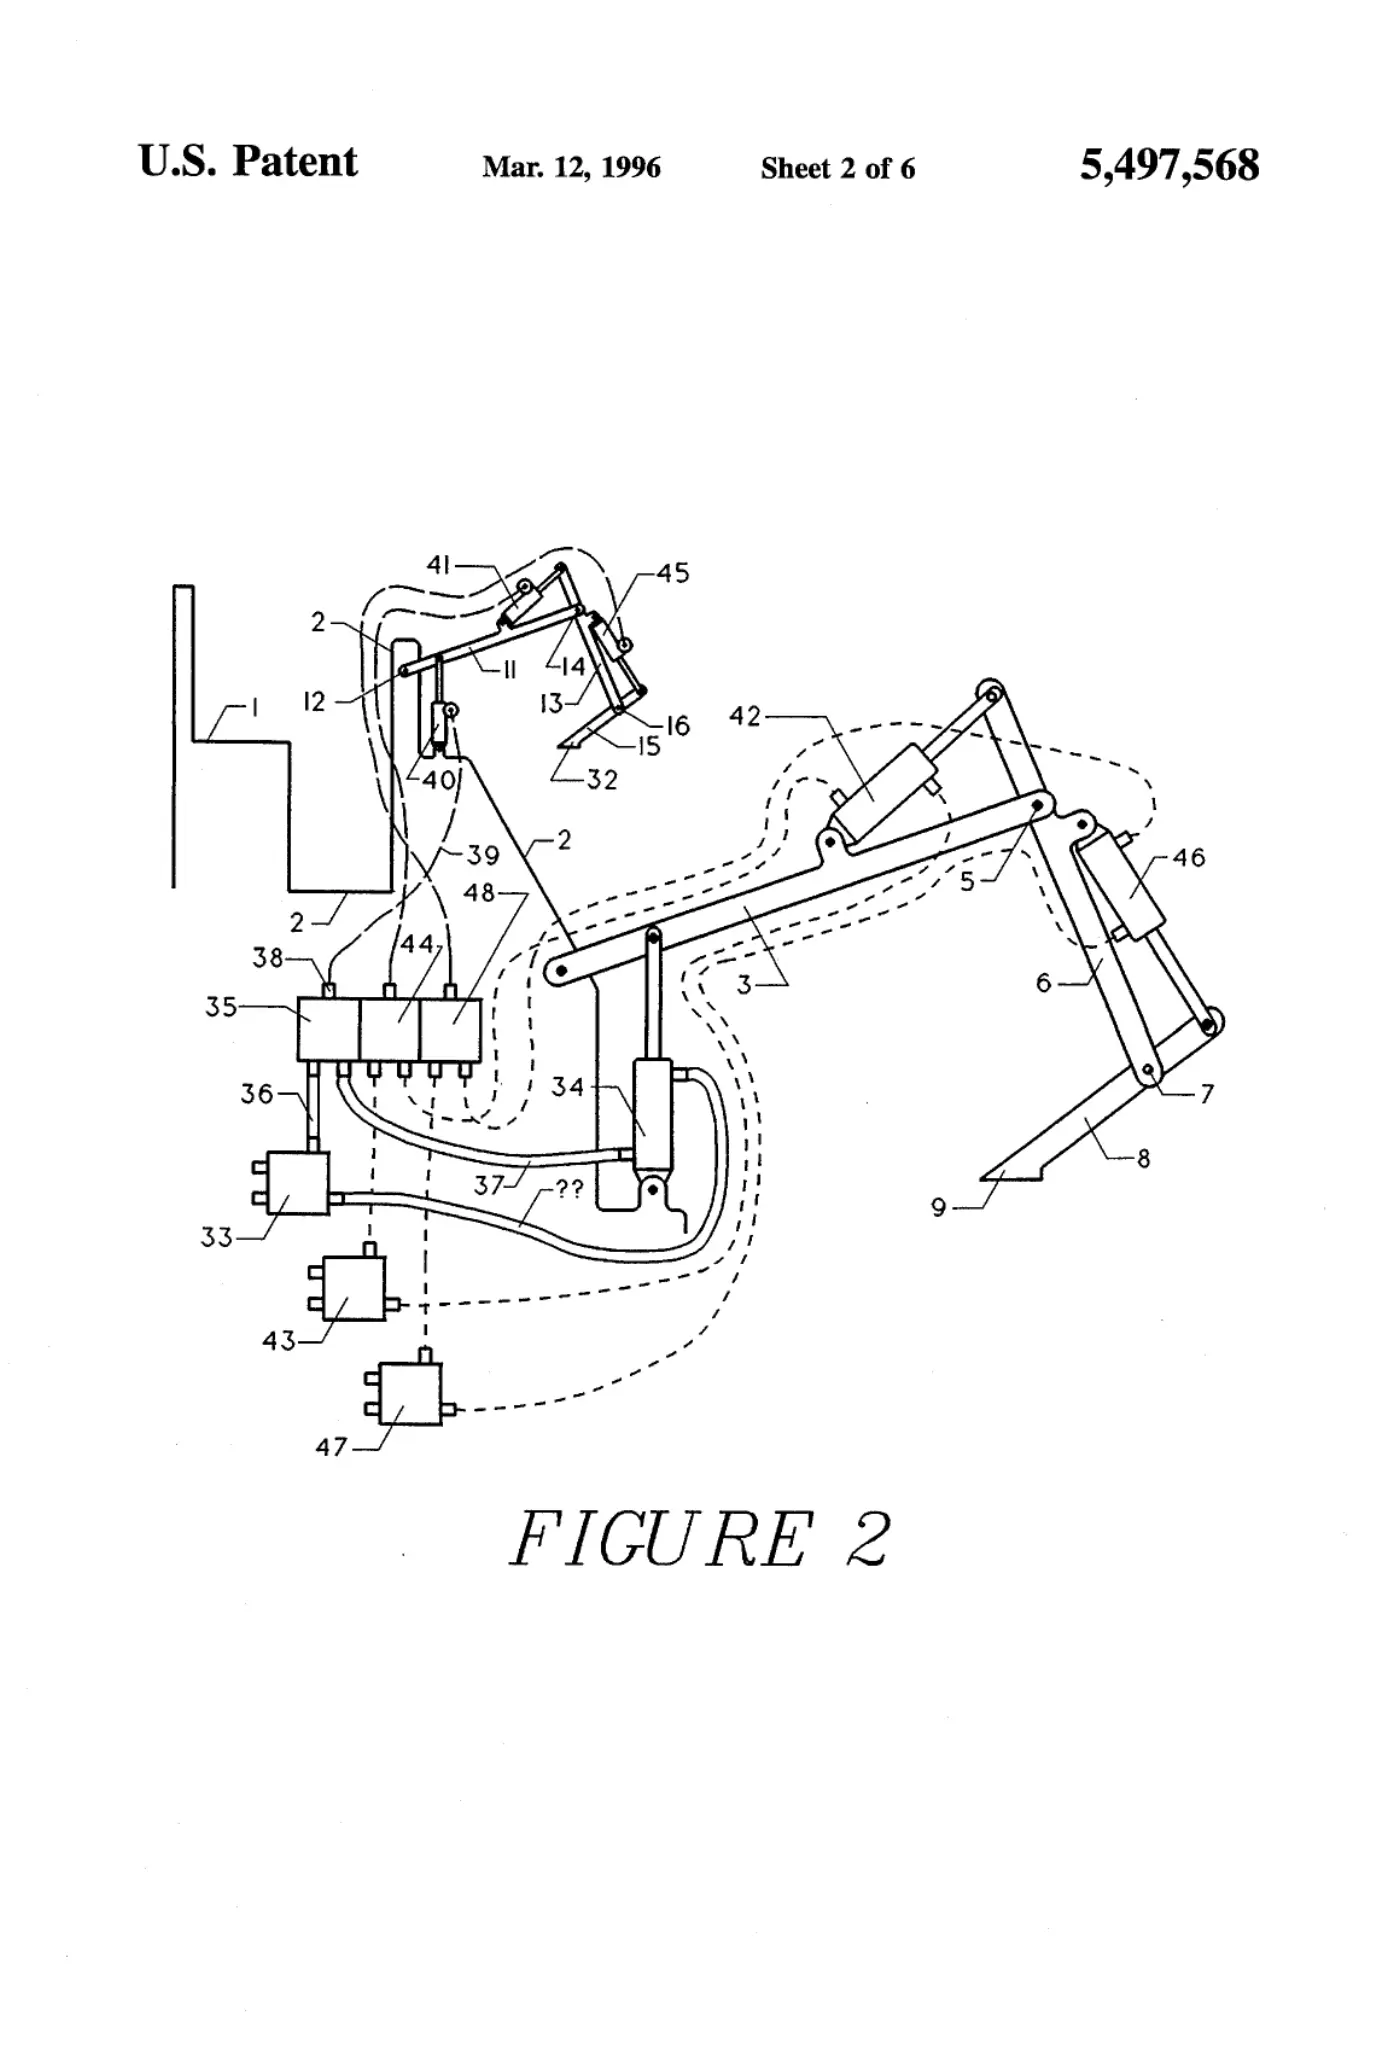
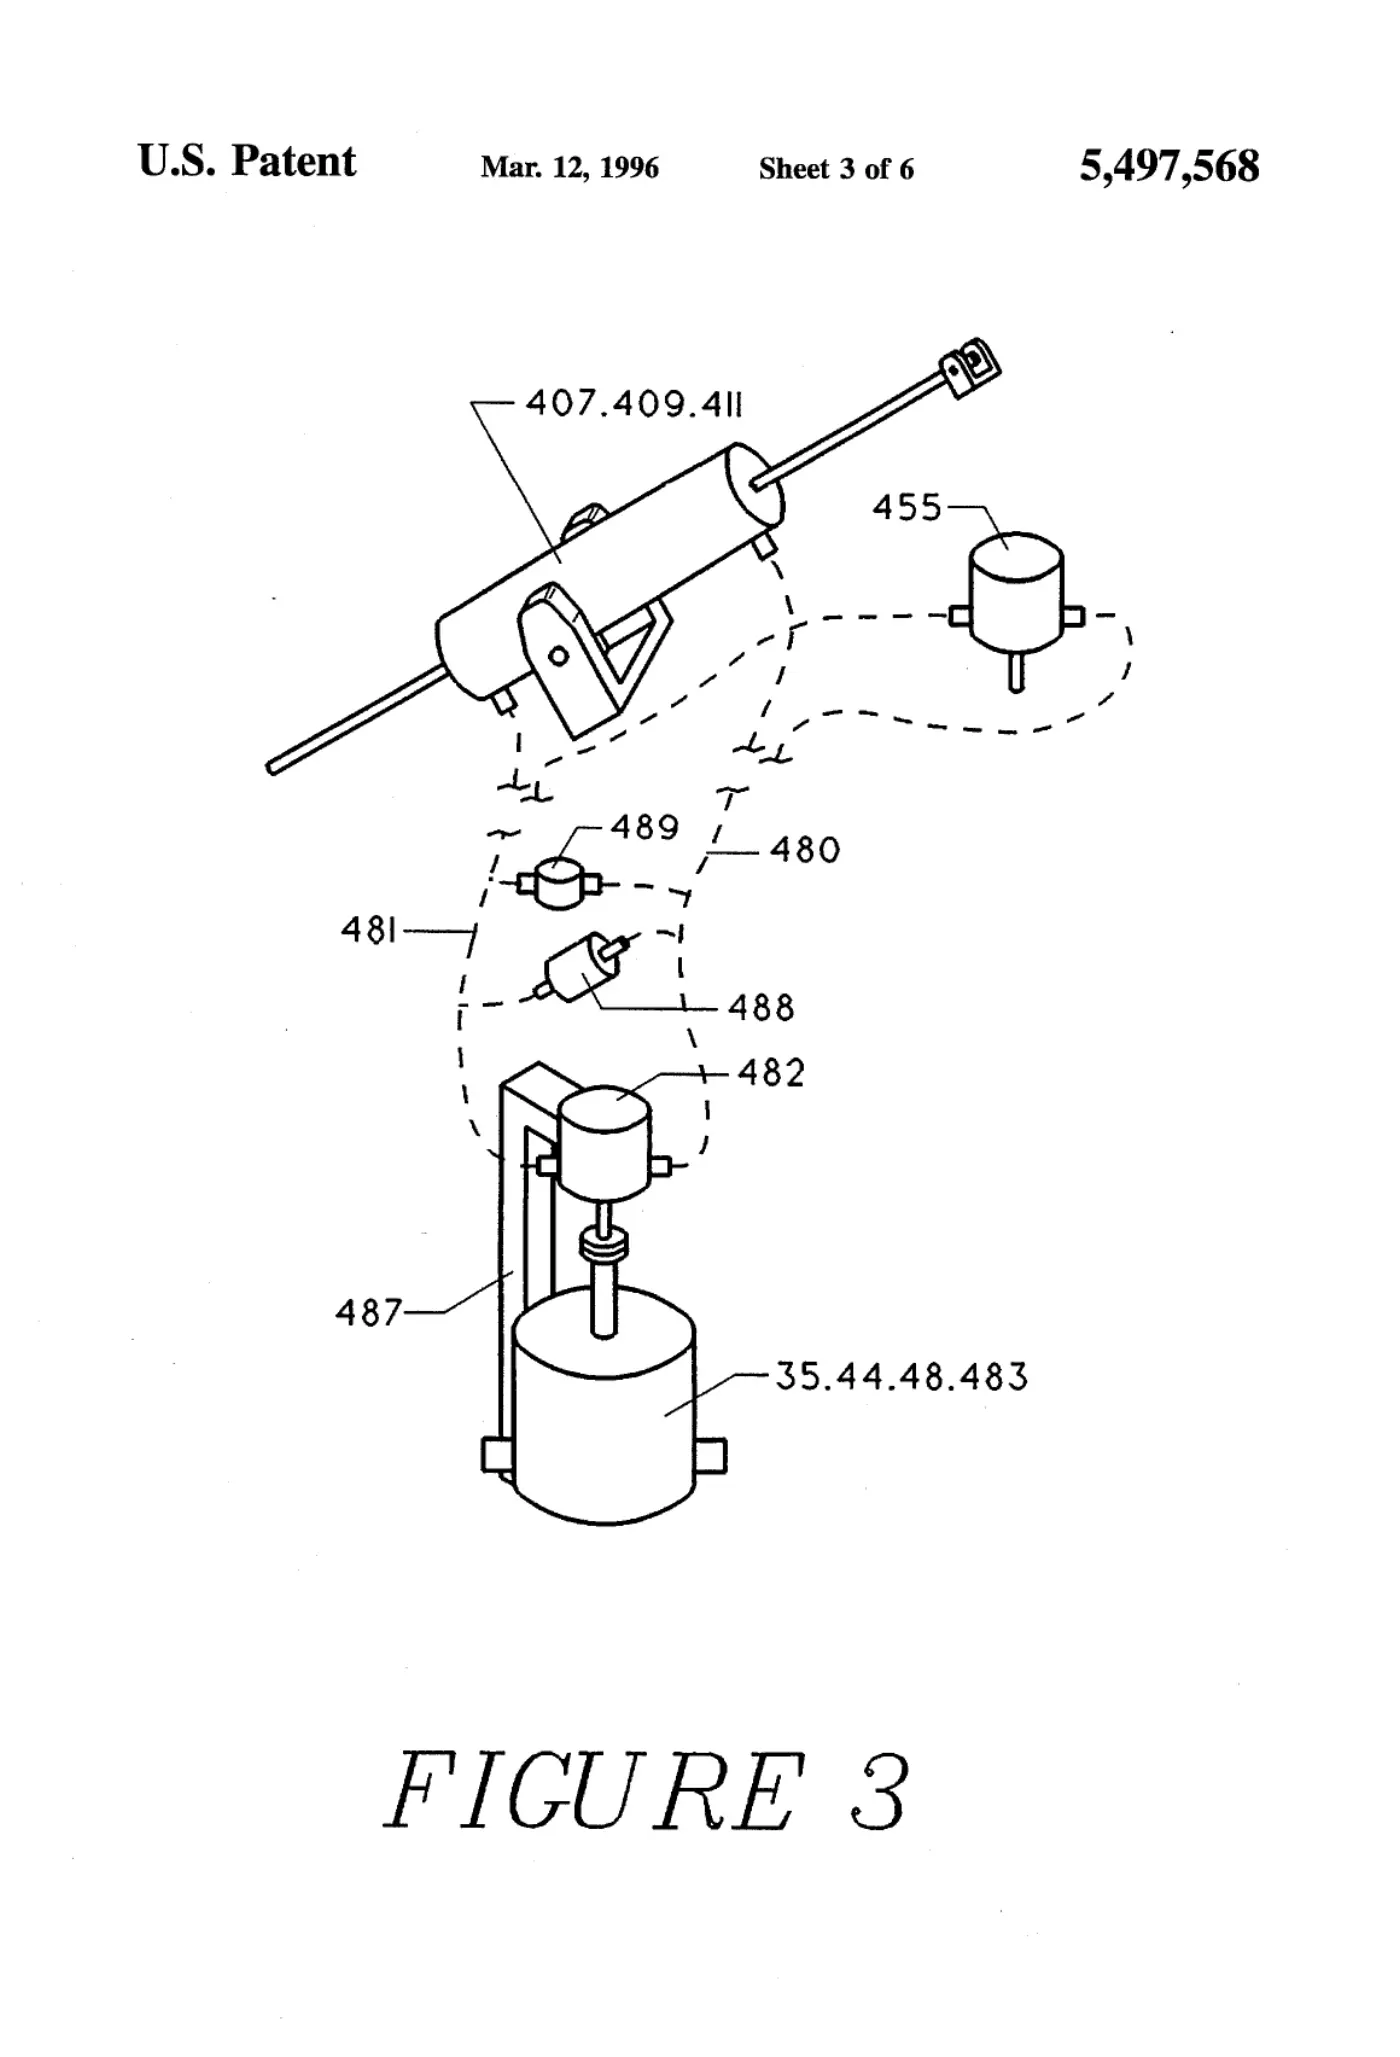
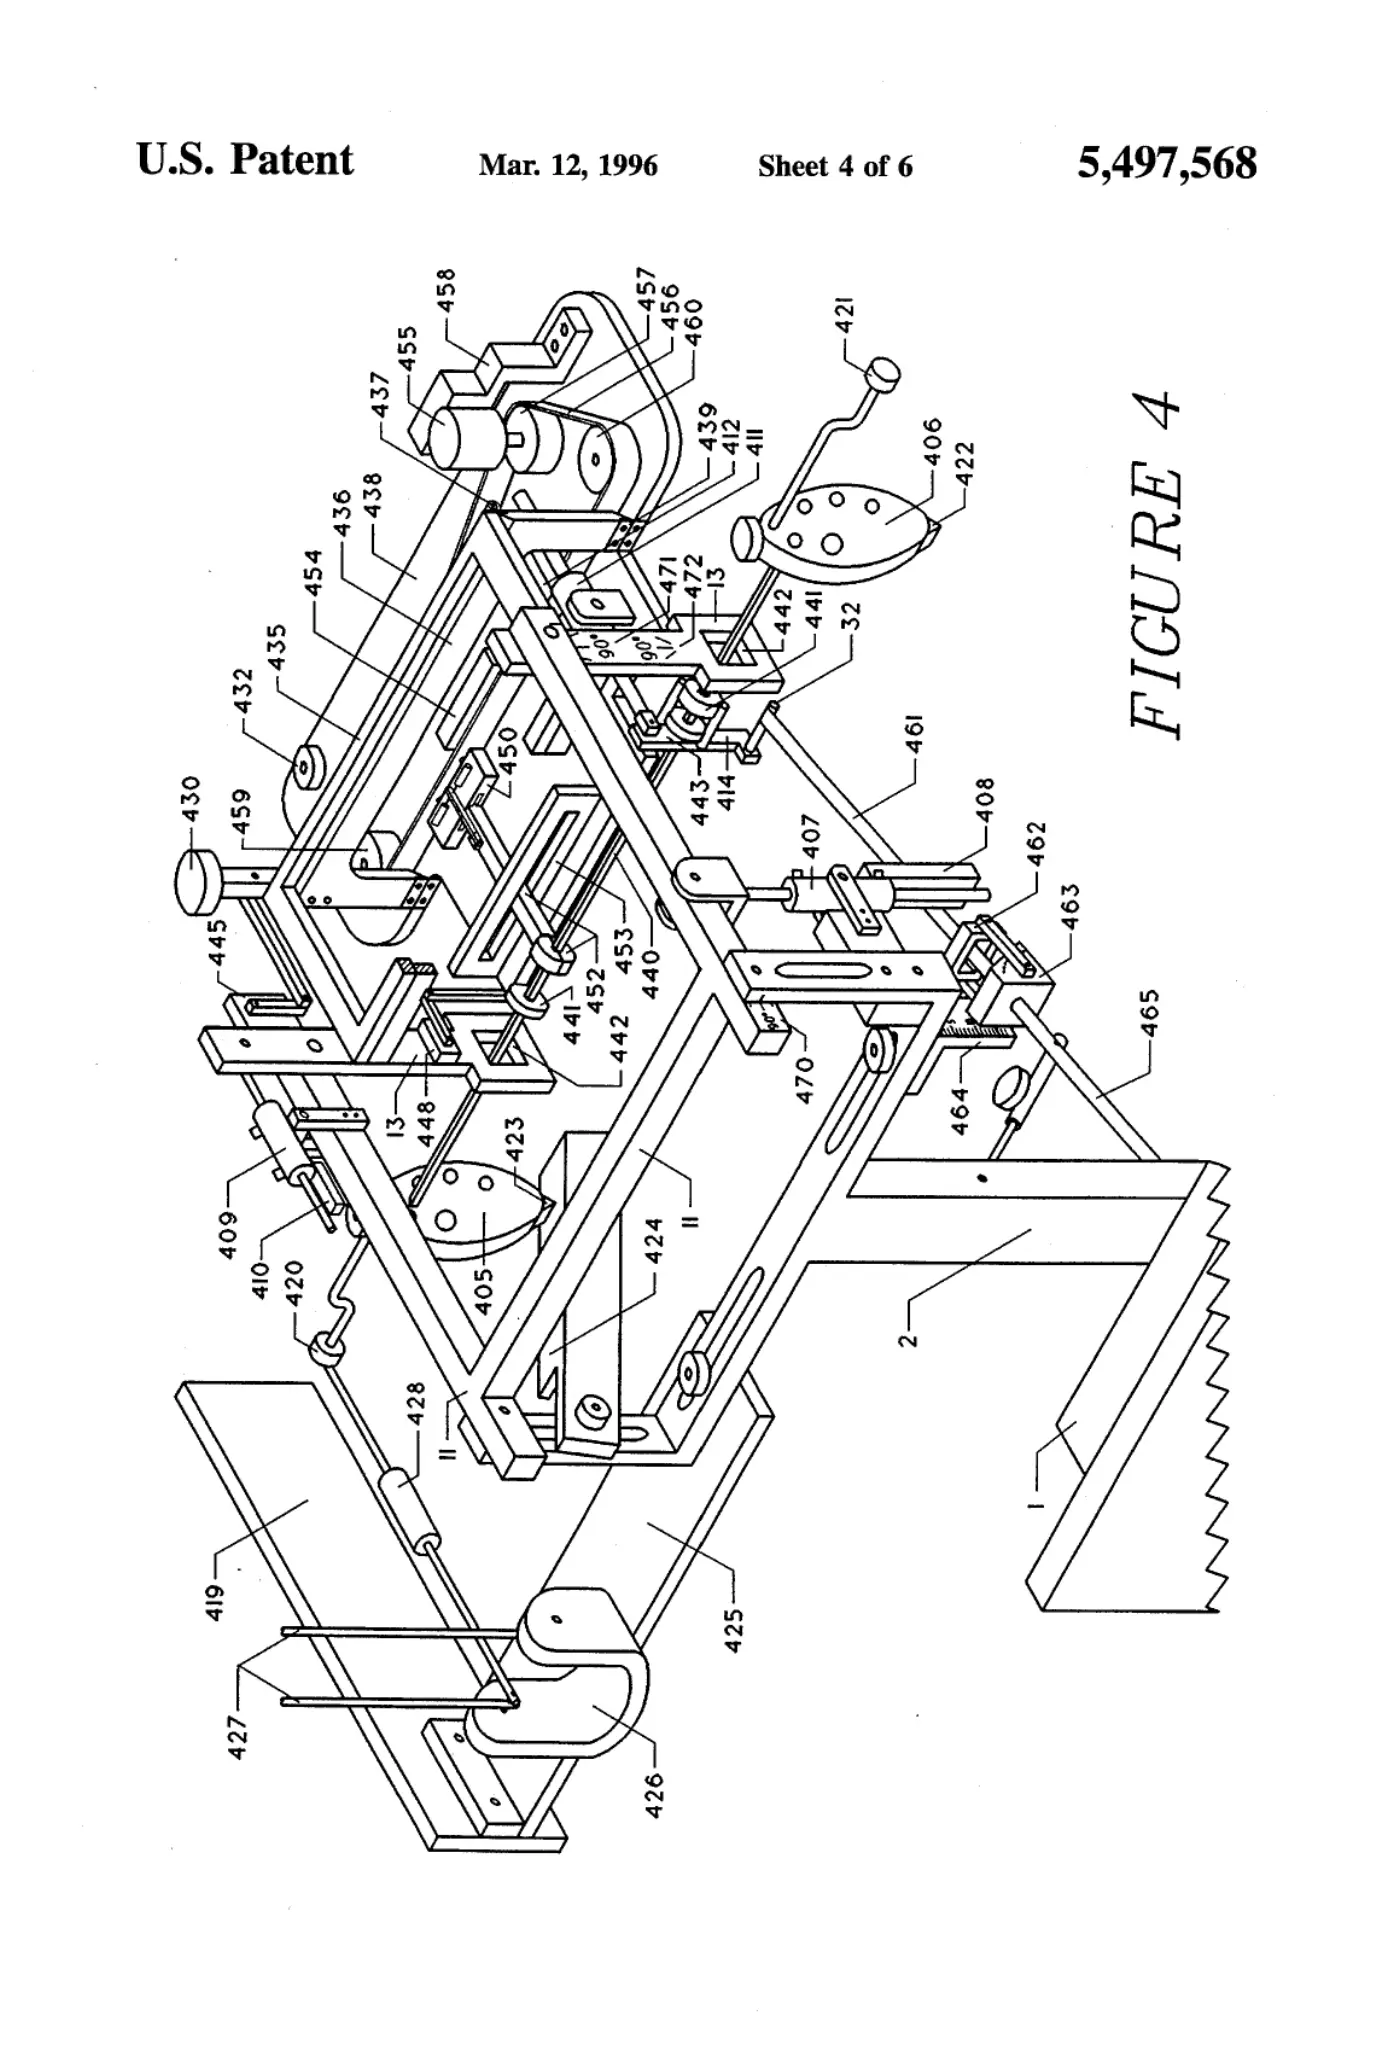
A system for controlling a track propelled excavator that has an allowable 360 degree swing arc including: (a), a positioning controller for all five (propel, swing, boom, arm,and bucket) motions: (b), positioning of small members that represent the large deck, boom, arm, and bracket by a flow of fluid in series with each large member's actuator--eliminating a need for transmitting each digging member's angular position back to the controller; (c), a handle with tooth type edge that represents the large bucket, for scraping along templates for guiding desired earth contours; (d), guide plates and positioning switches for acheiving accurate and safe placement of the bucket during swing and digging motions; (e), a mobile armrest that allows ease of operator's small scale motions when guiding large scale digging: (f), and, an assembly for pulling the small bucket/handle through a series of desired small scale positions to achieve automatic trench digging.
Abstract
A system for controlling a track propelled excavator that has an allowable 360 degree swing arc including: (a), a positioning controller for all five (propel, swing, boom, arm,and bucket) motions: (b), positioning of small members that represent the large deck, boom, arm, and bracket by a flow of fluid in series with each large member's actuator--eliminating a need for transmitting each digging member's angular position back to the controller; (c), a handle with tooth type edge that represents the large bucket, for scraping along templates for guiding desired earth contours; (d), guide plates and positioning switches for acheiving accurate and safe placement of the bucket during swing and digging motions; (e), a mobile armrest that allows ease of operator's small scale motions when guiding large scale digging: (f), and, an assembly for pulling the small bucket/handle through a series of desired small scale positions to achieve automatic trench digging.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
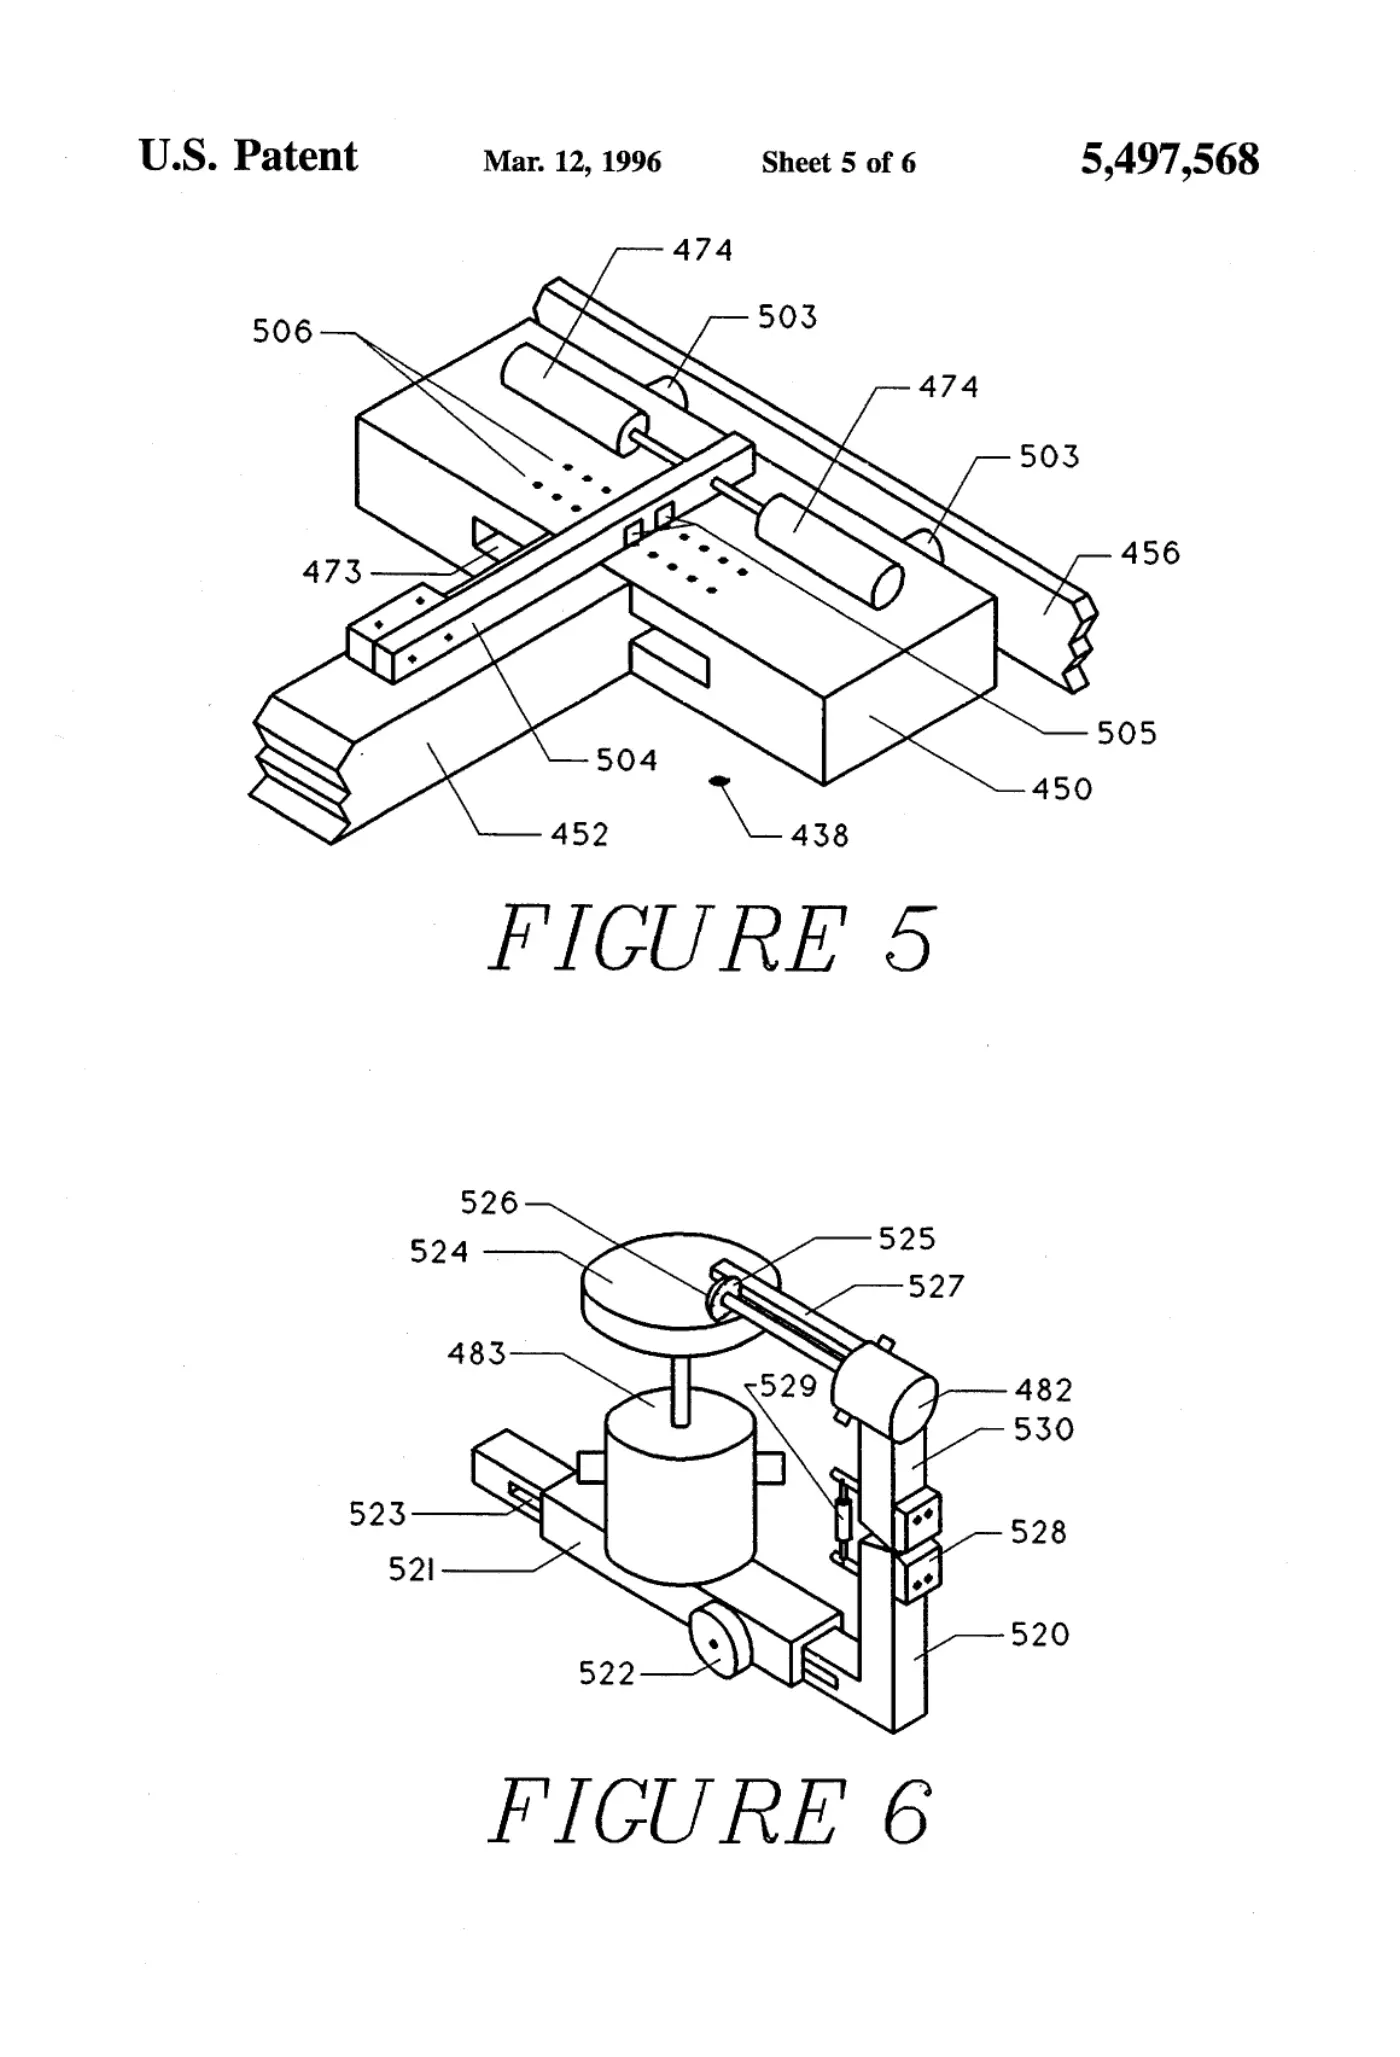
[0005]Sheet 5.
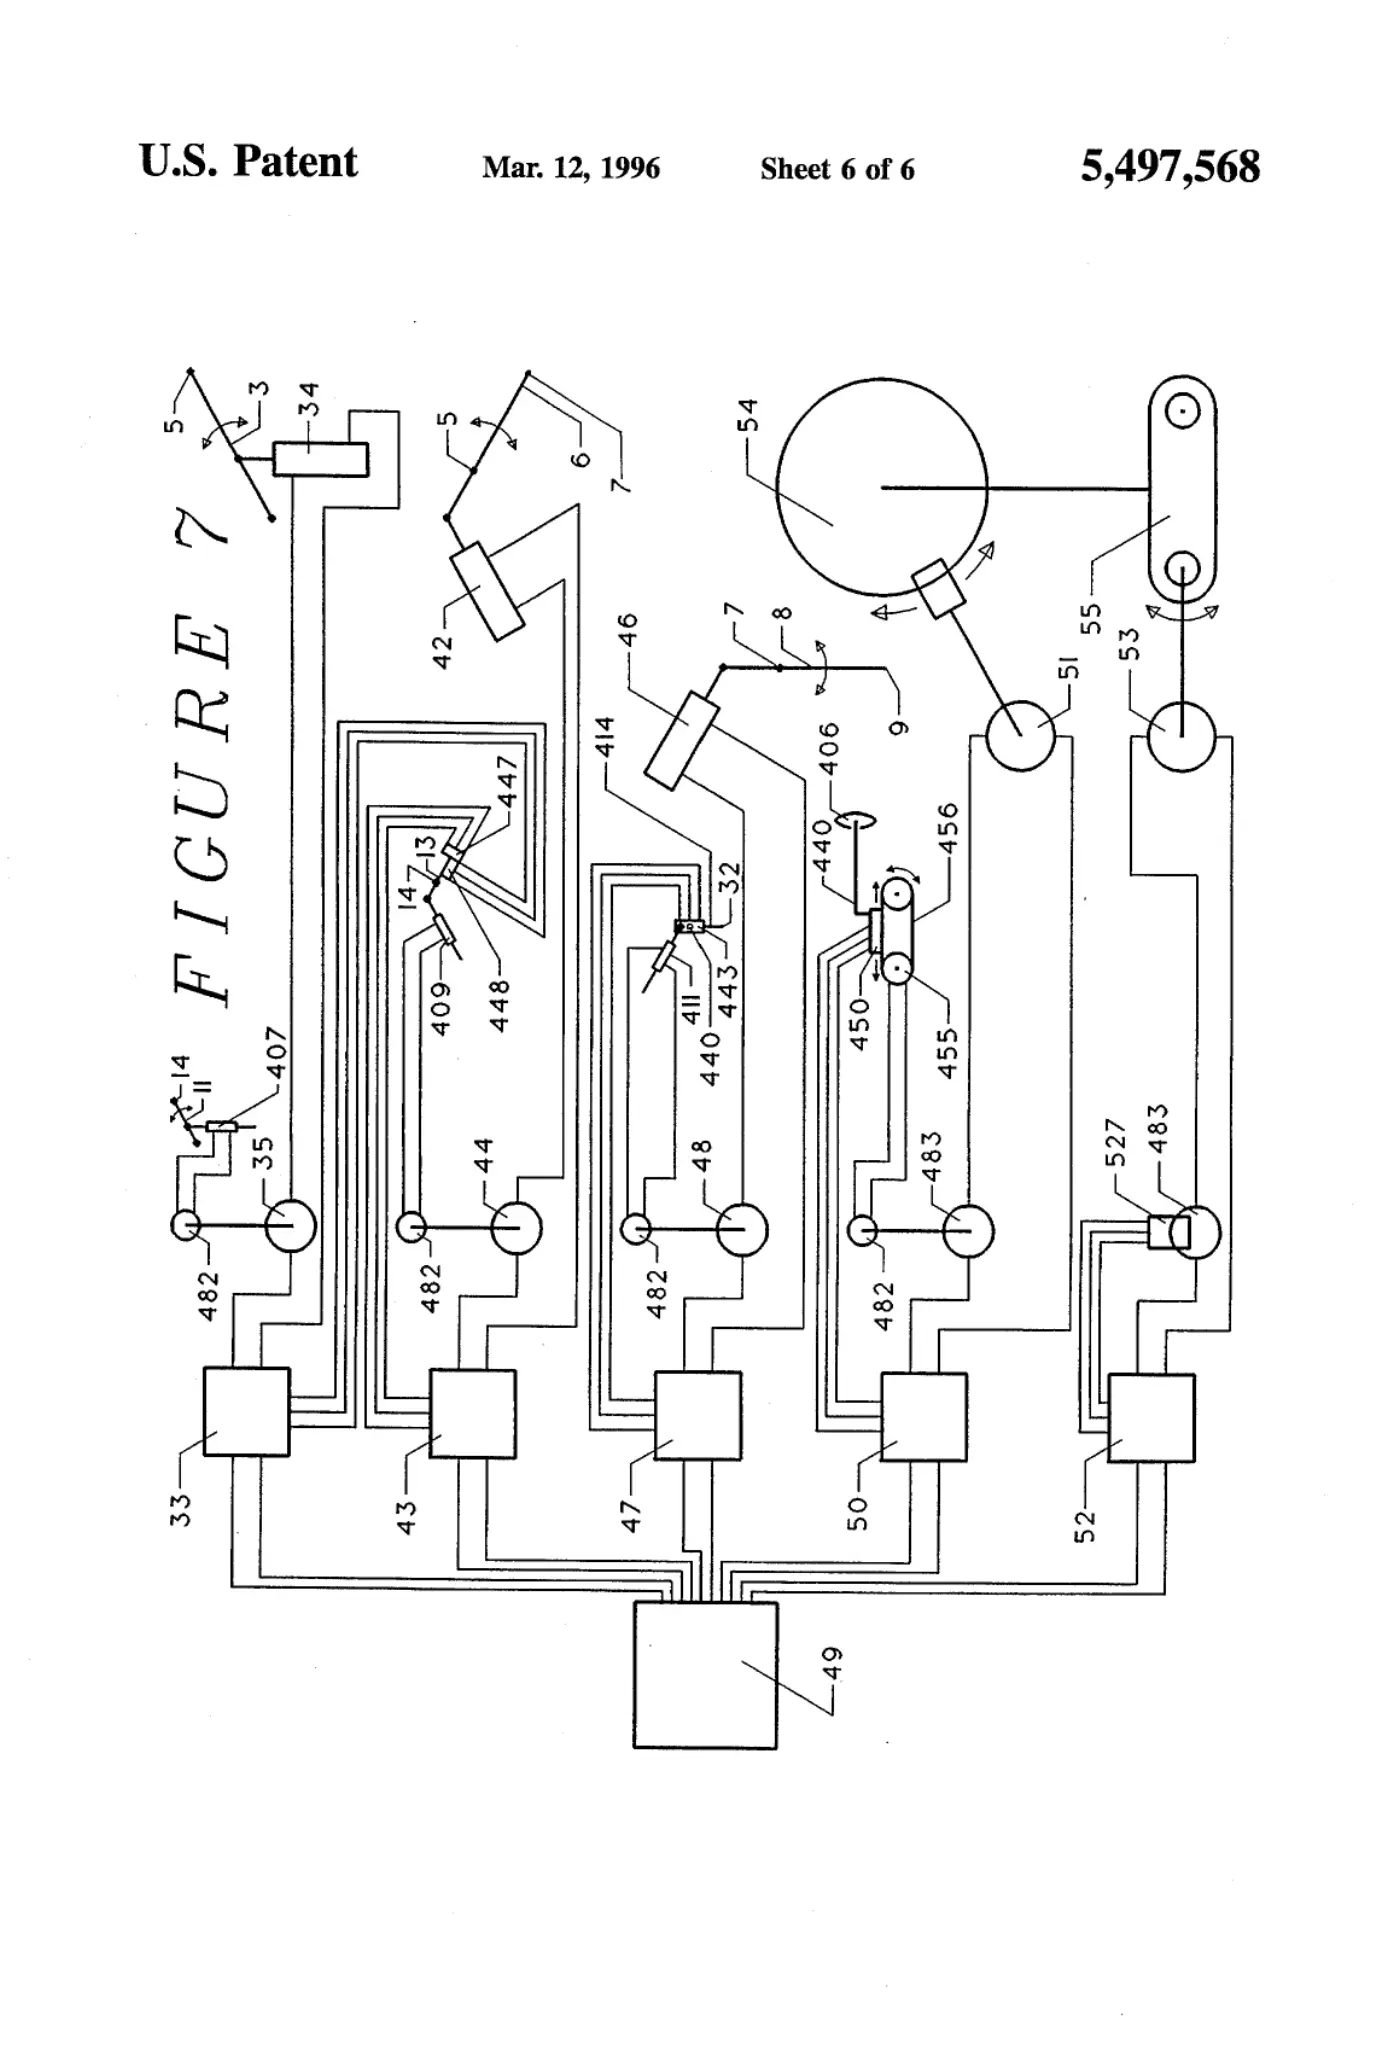
[0006]Sheet 6.
Publication information
Citation
OpenTechnical Publication OT-2026-000003288, “Integrated group of excavator control assemblies,” published September 15, 2026 at 20:03:14 UTC, https://opentechnical.org/p/OT-2026-000003288.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.