OT-2026-000003308
Coordinated control for a work implement
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003308
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- ALLEN WILLIAM E, ANDERSON PAUL D, BRADBURY WALTER J, HADANK JOHN M, LEAGUE RICHARD B
- Assignee
- CATERPILLAR INC
- Original source
- US-5424623-A, the United States Patent and Trademark Office, 13 June 1995
- Document SHA-256
- 35df67e8b48b2994e18a460557365cfad8682c34d9eb3bca1a2cc1016daa2b4a
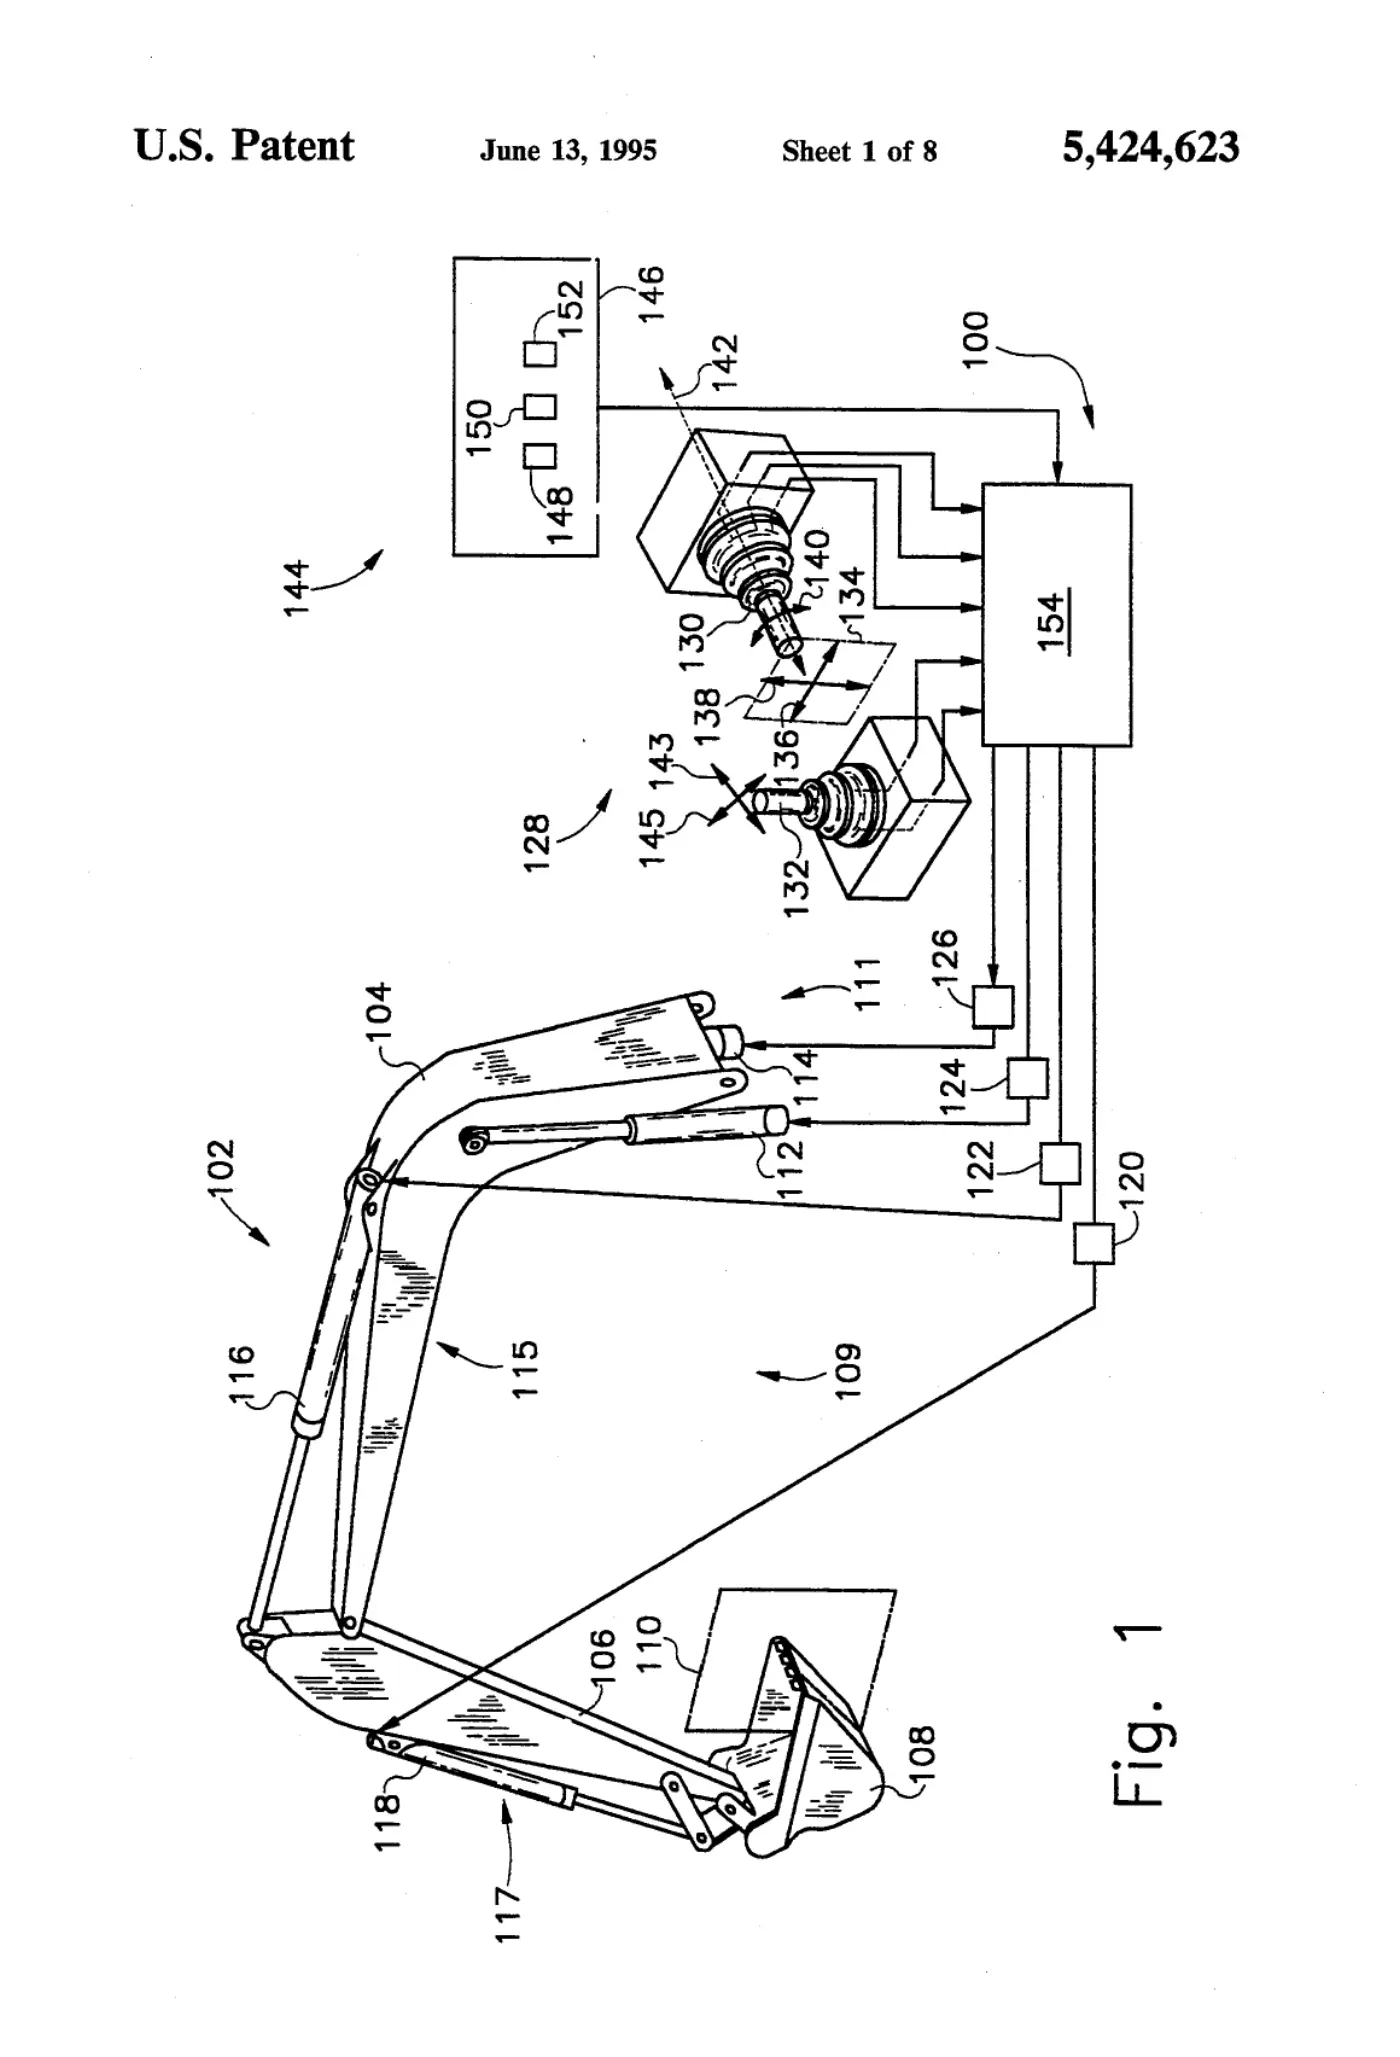
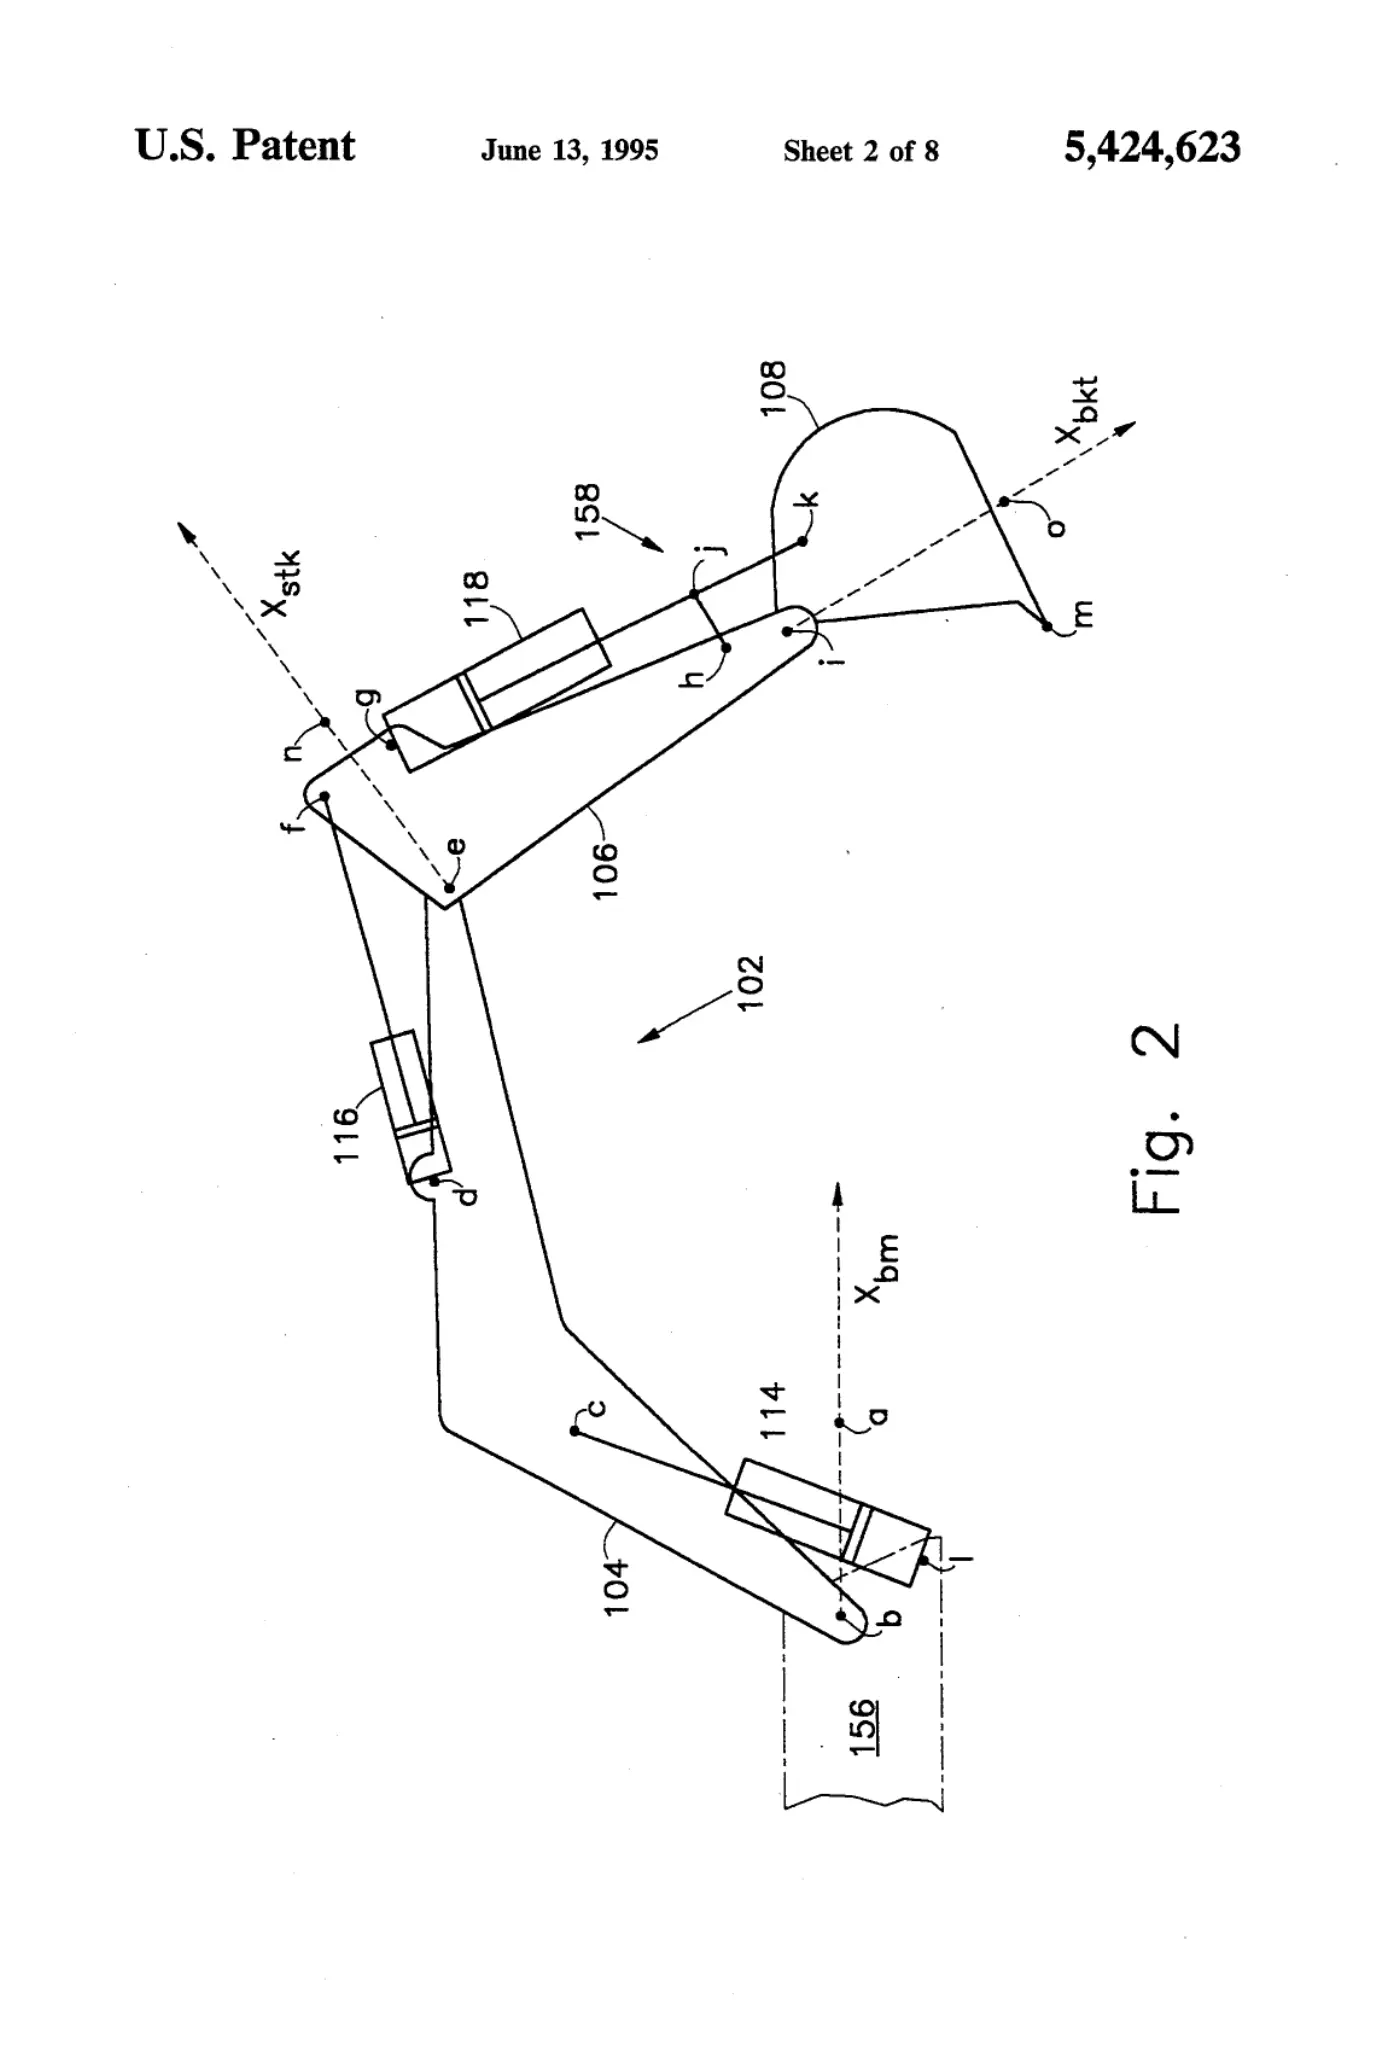
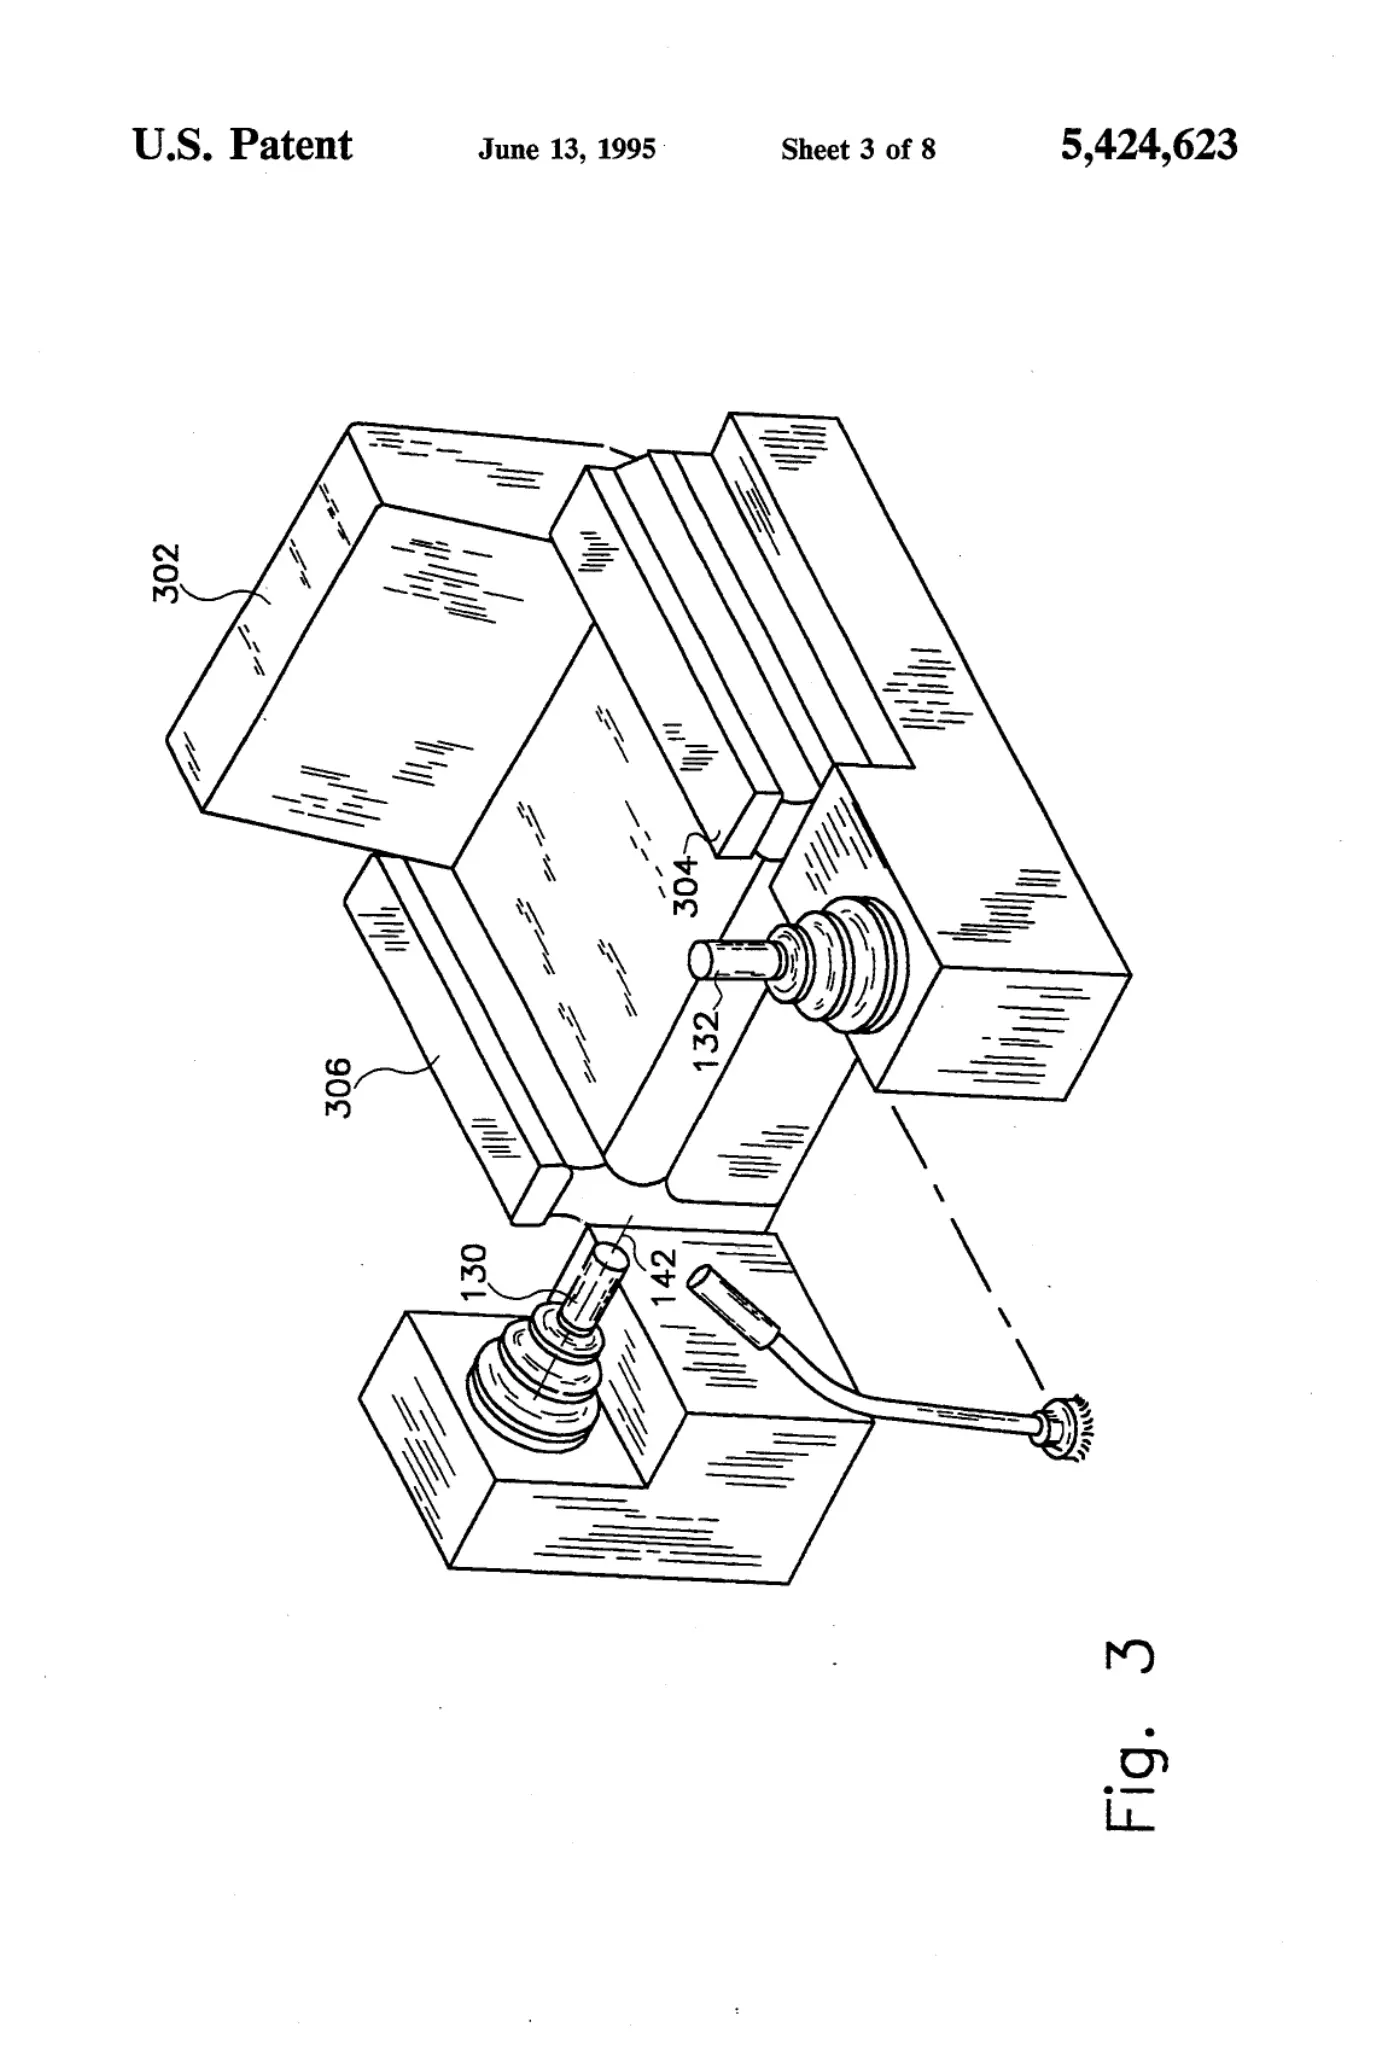
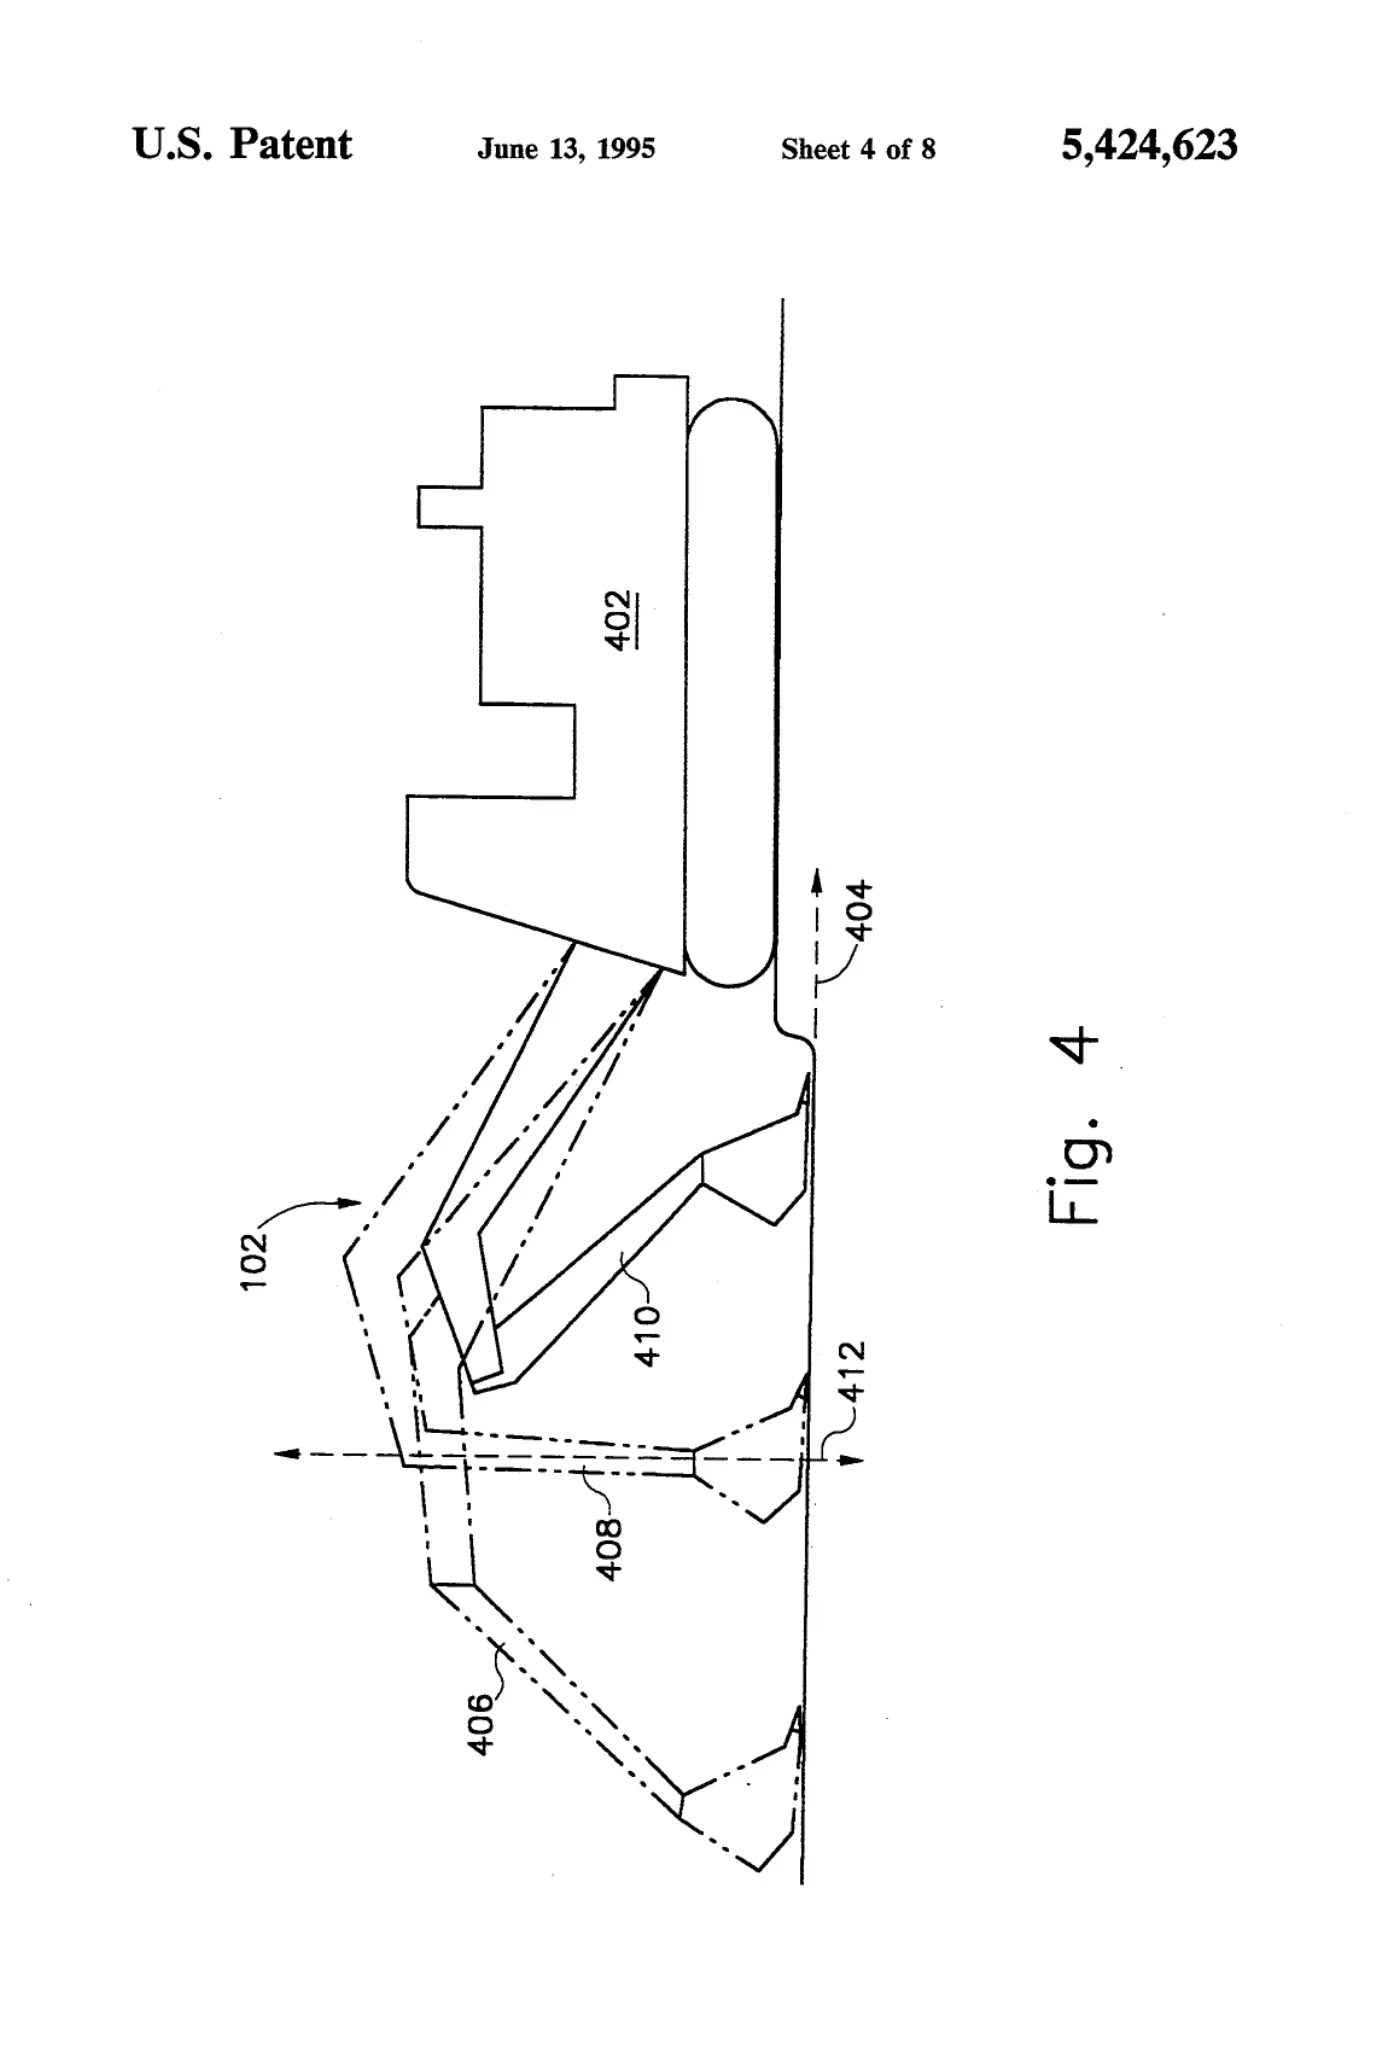
The present invention provides, an apparatus for controllably moving a vehicle's work implement. The work implement includes a first appendage pivotally connected to the vehicle, and a second appendage pivotally connected to the first appendage. The apparatus senses the geometry of the work implement and responsibly producing a plurality of position signal and produces one of a manual control mode signal and an automatic control mode signal. An operator interface produces first and second lever command signals indicative of desired movement of the work implement. The apparatus receives the one control mode signal and the first and second lever control signals and responsively produces linear motion of the end point of the second appendage along first and second work axes if the one control mode signal is equal to the automatic control mode signal.
Abstract
The present invention provides, an apparatus for controllably moving a vehicle's work implement. The work implement includes a first appendage pivotally connected to the vehicle, and a second appendage pivotally connected to the first appendage. The apparatus senses the geometry of the work implement and responsibly producing a plurality of position signal and produces one of a manual control mode signal and an automatic control mode signal. An operator interface produces first and second lever command signals indicative of desired movement of the work implement. The apparatus receives the one control mode signal and the first and second lever control signals and responsively produces linear motion of the end point of the second appendage along first and second work axes if the one control mode signal is equal to the automatic control mode signal.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
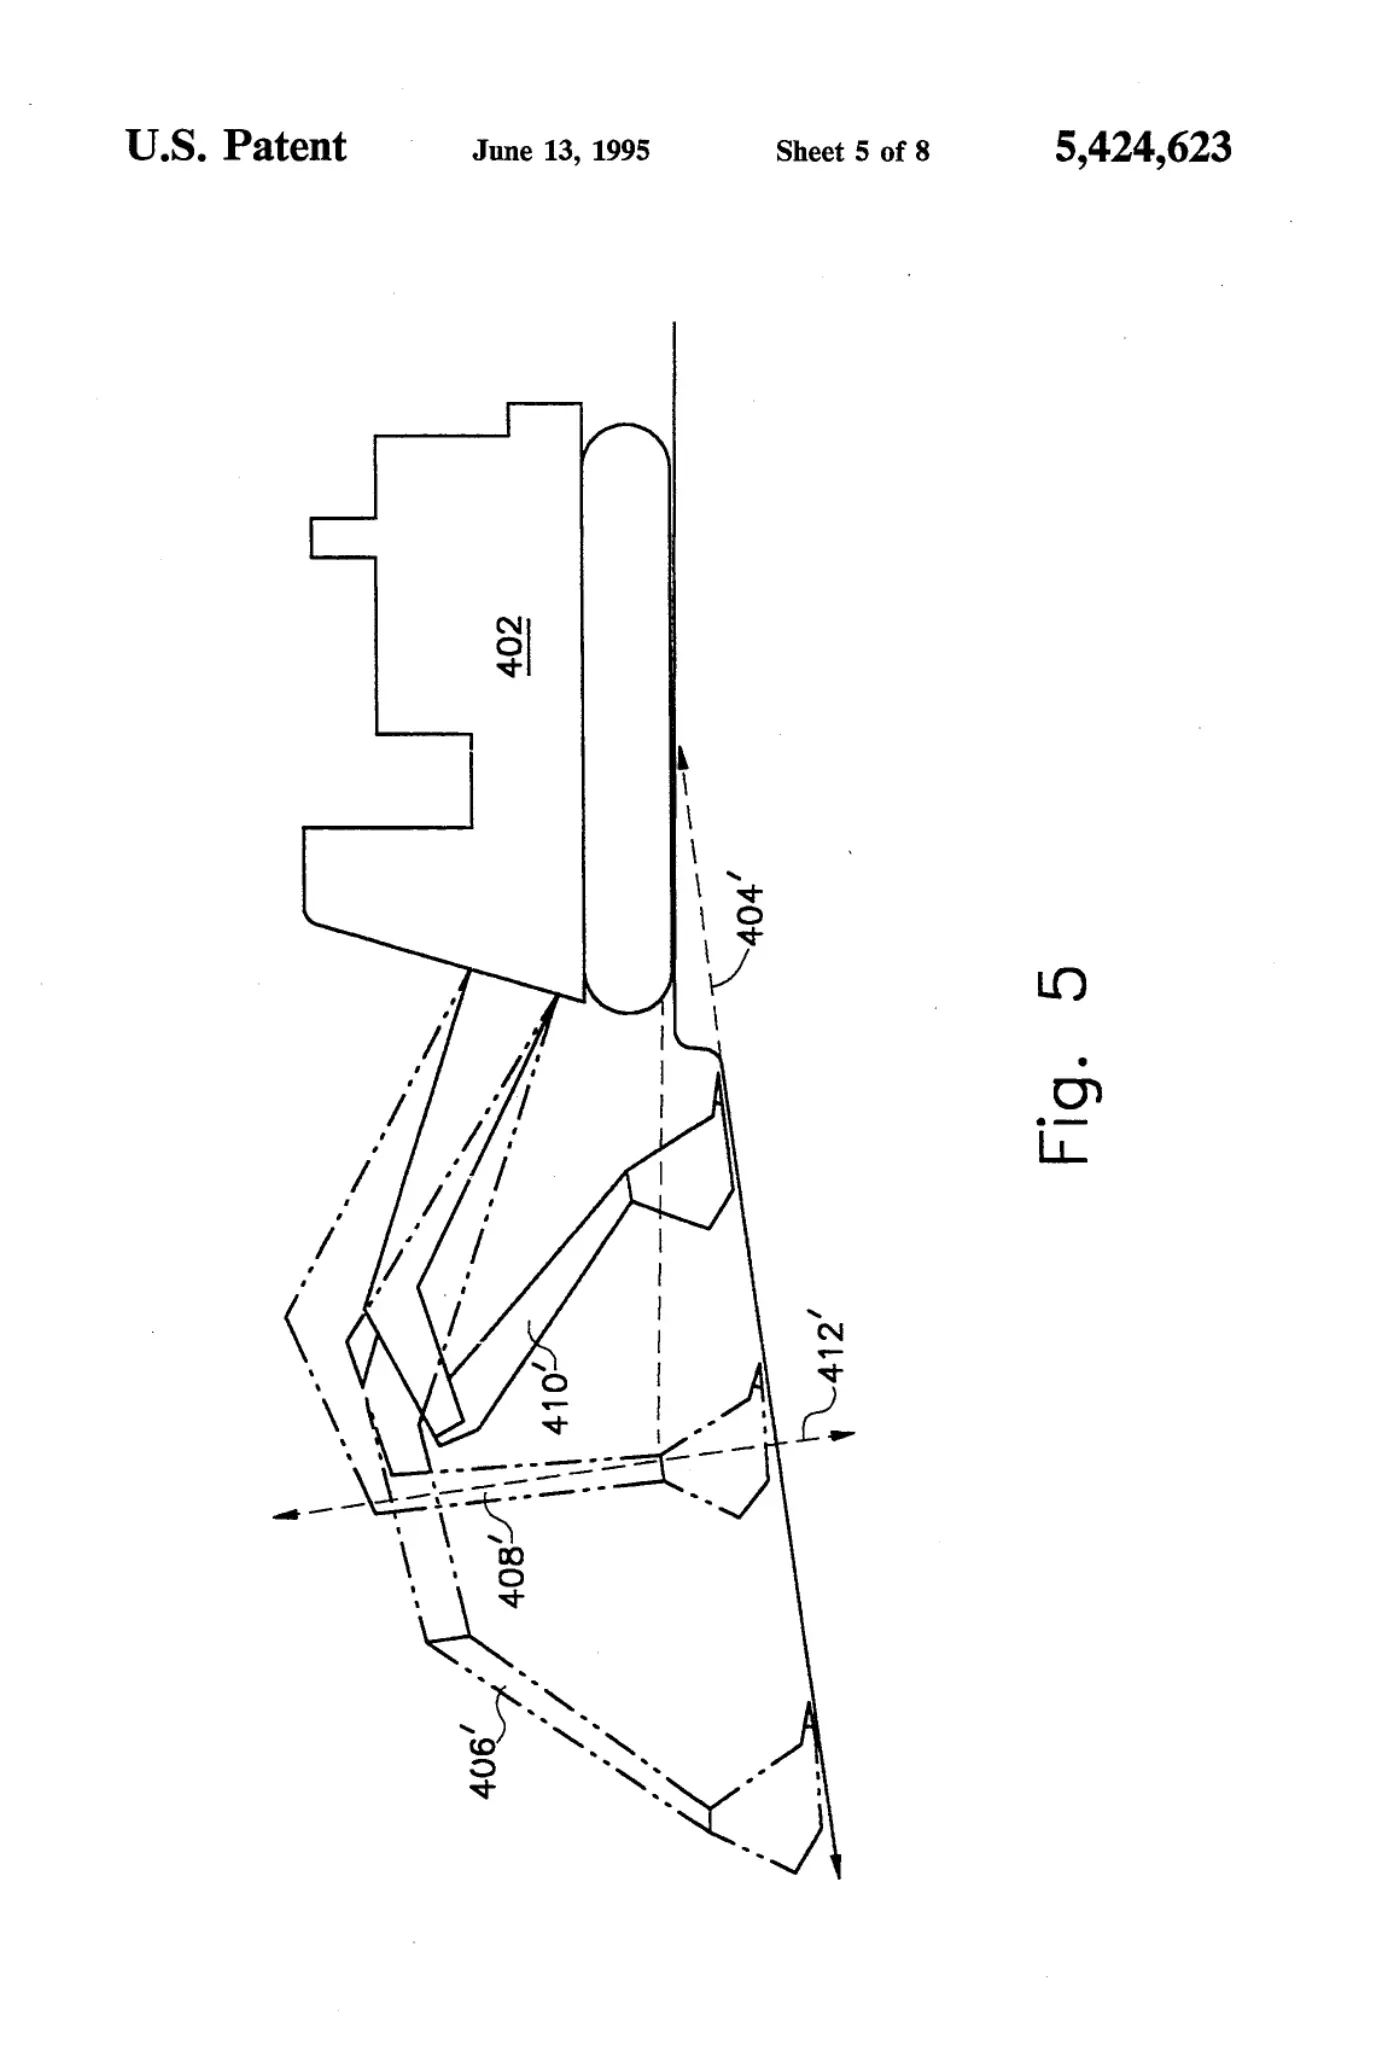
[0005]Sheet 5.
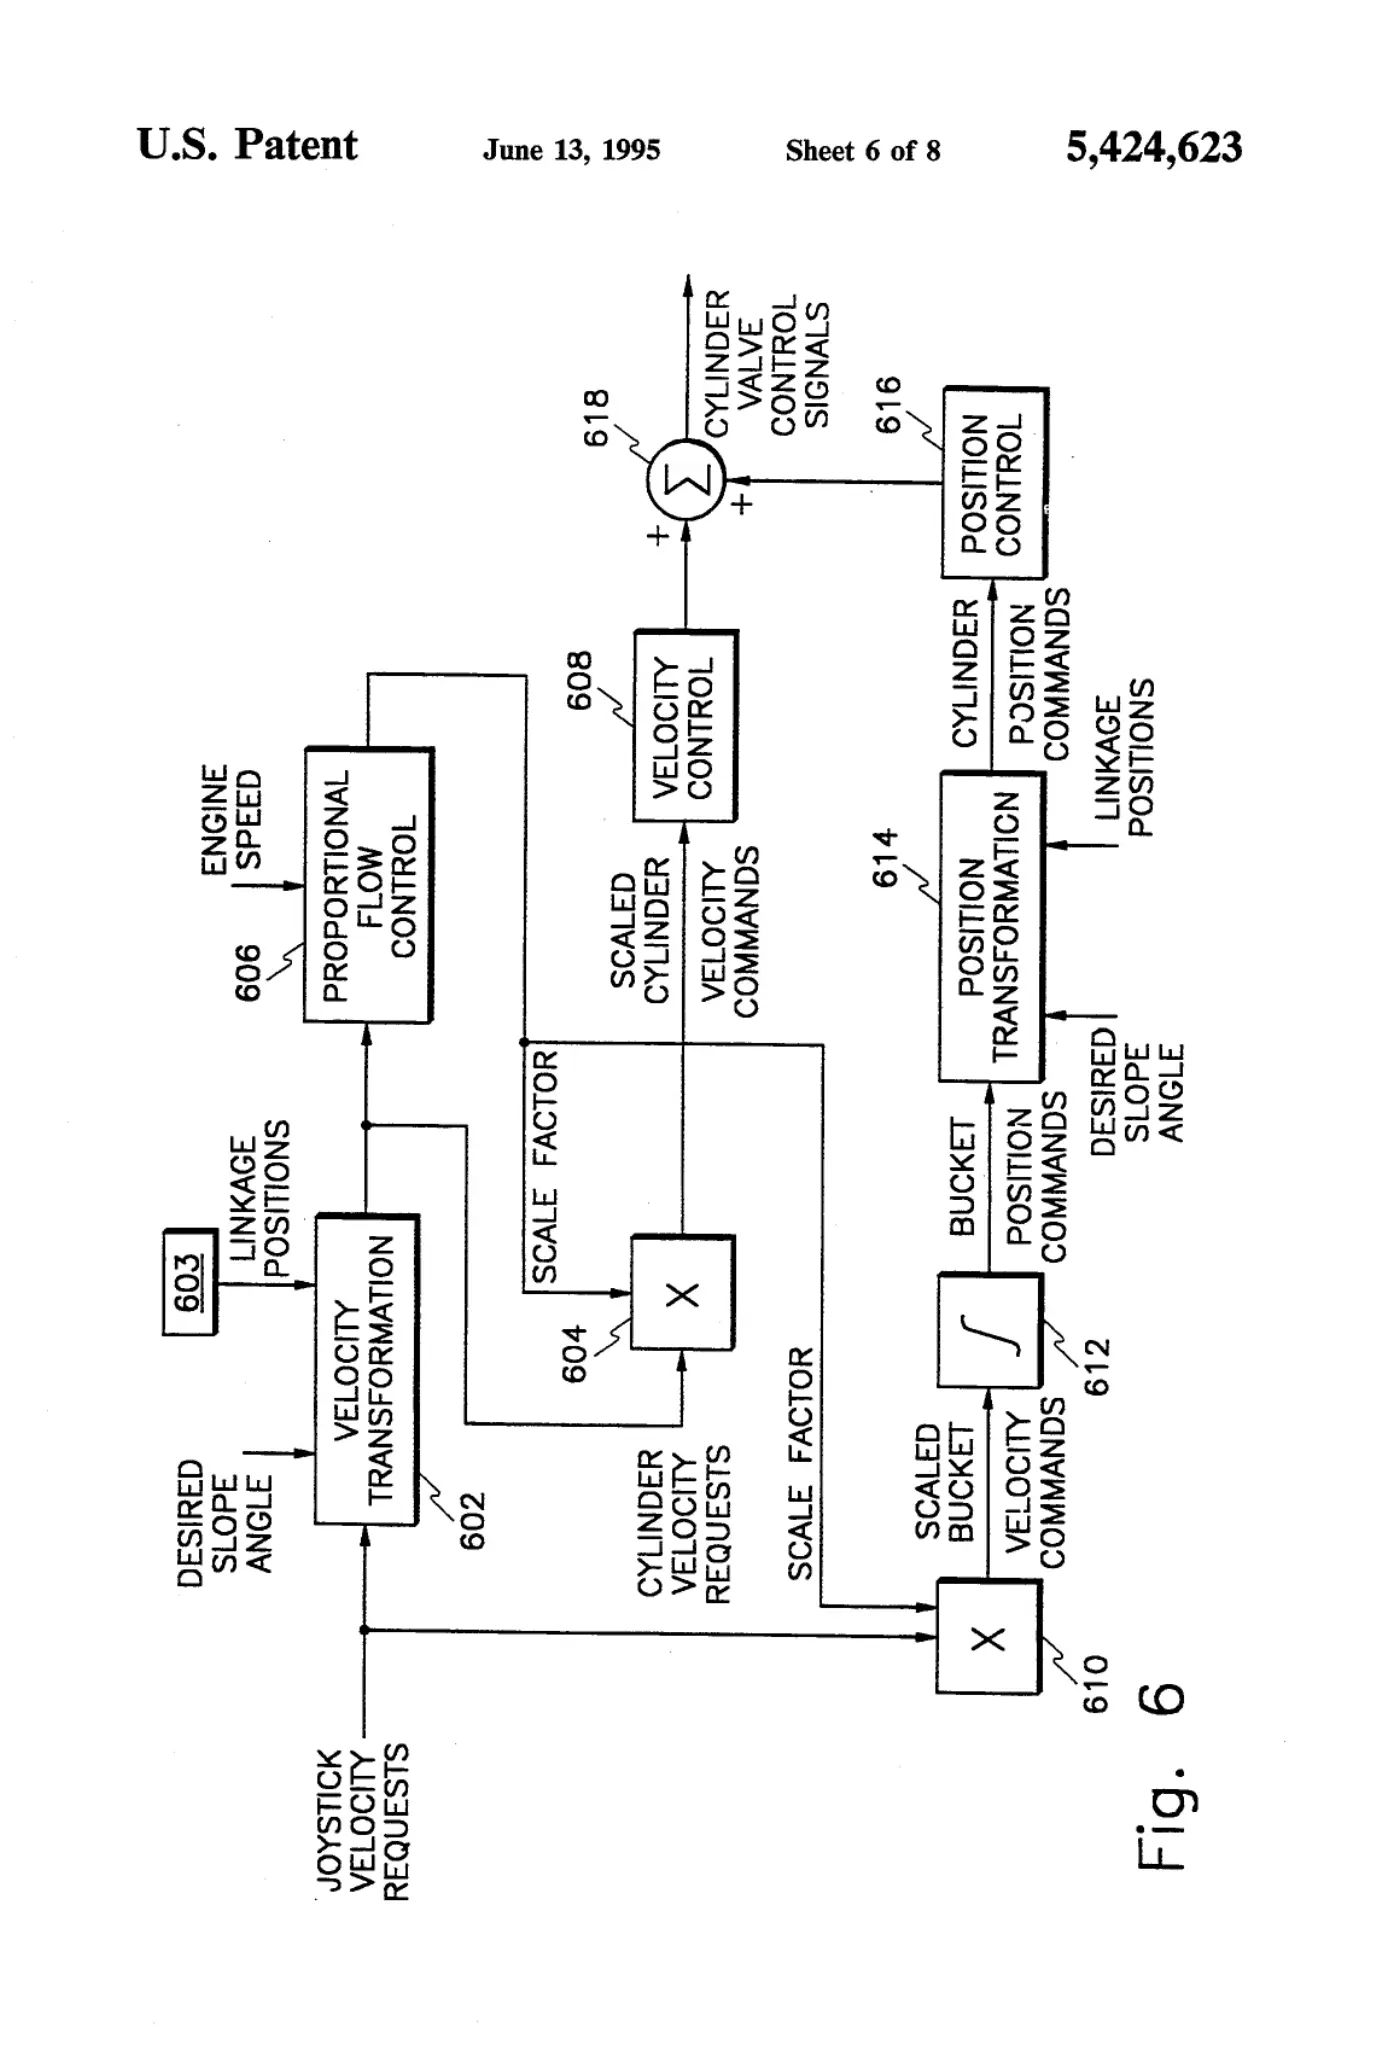
[0006]Sheet 6.
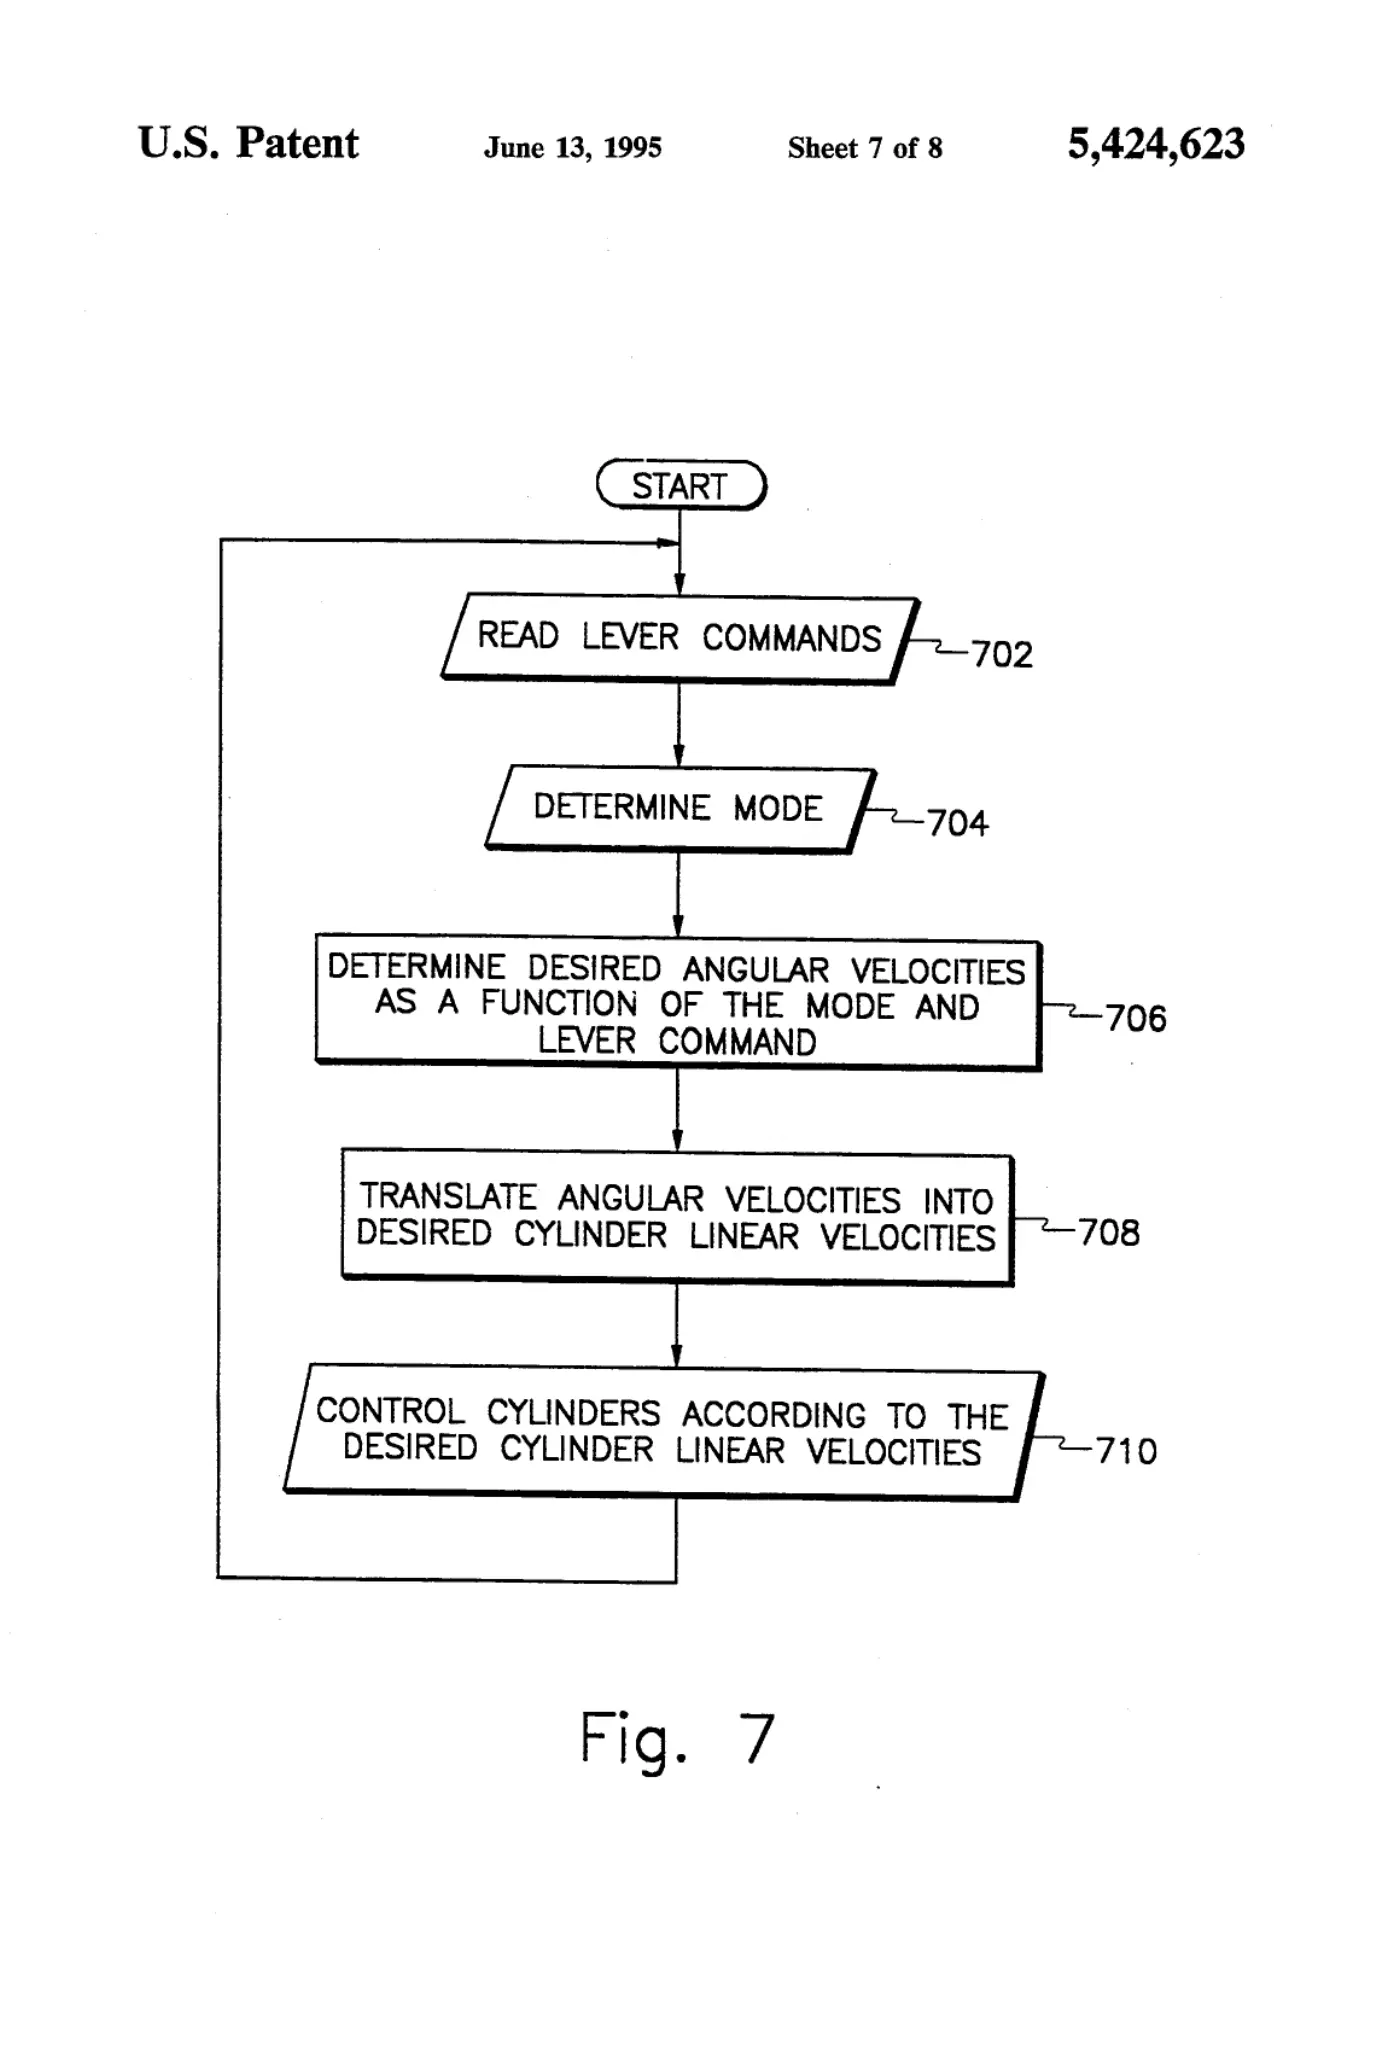
[0007]Sheet 7.
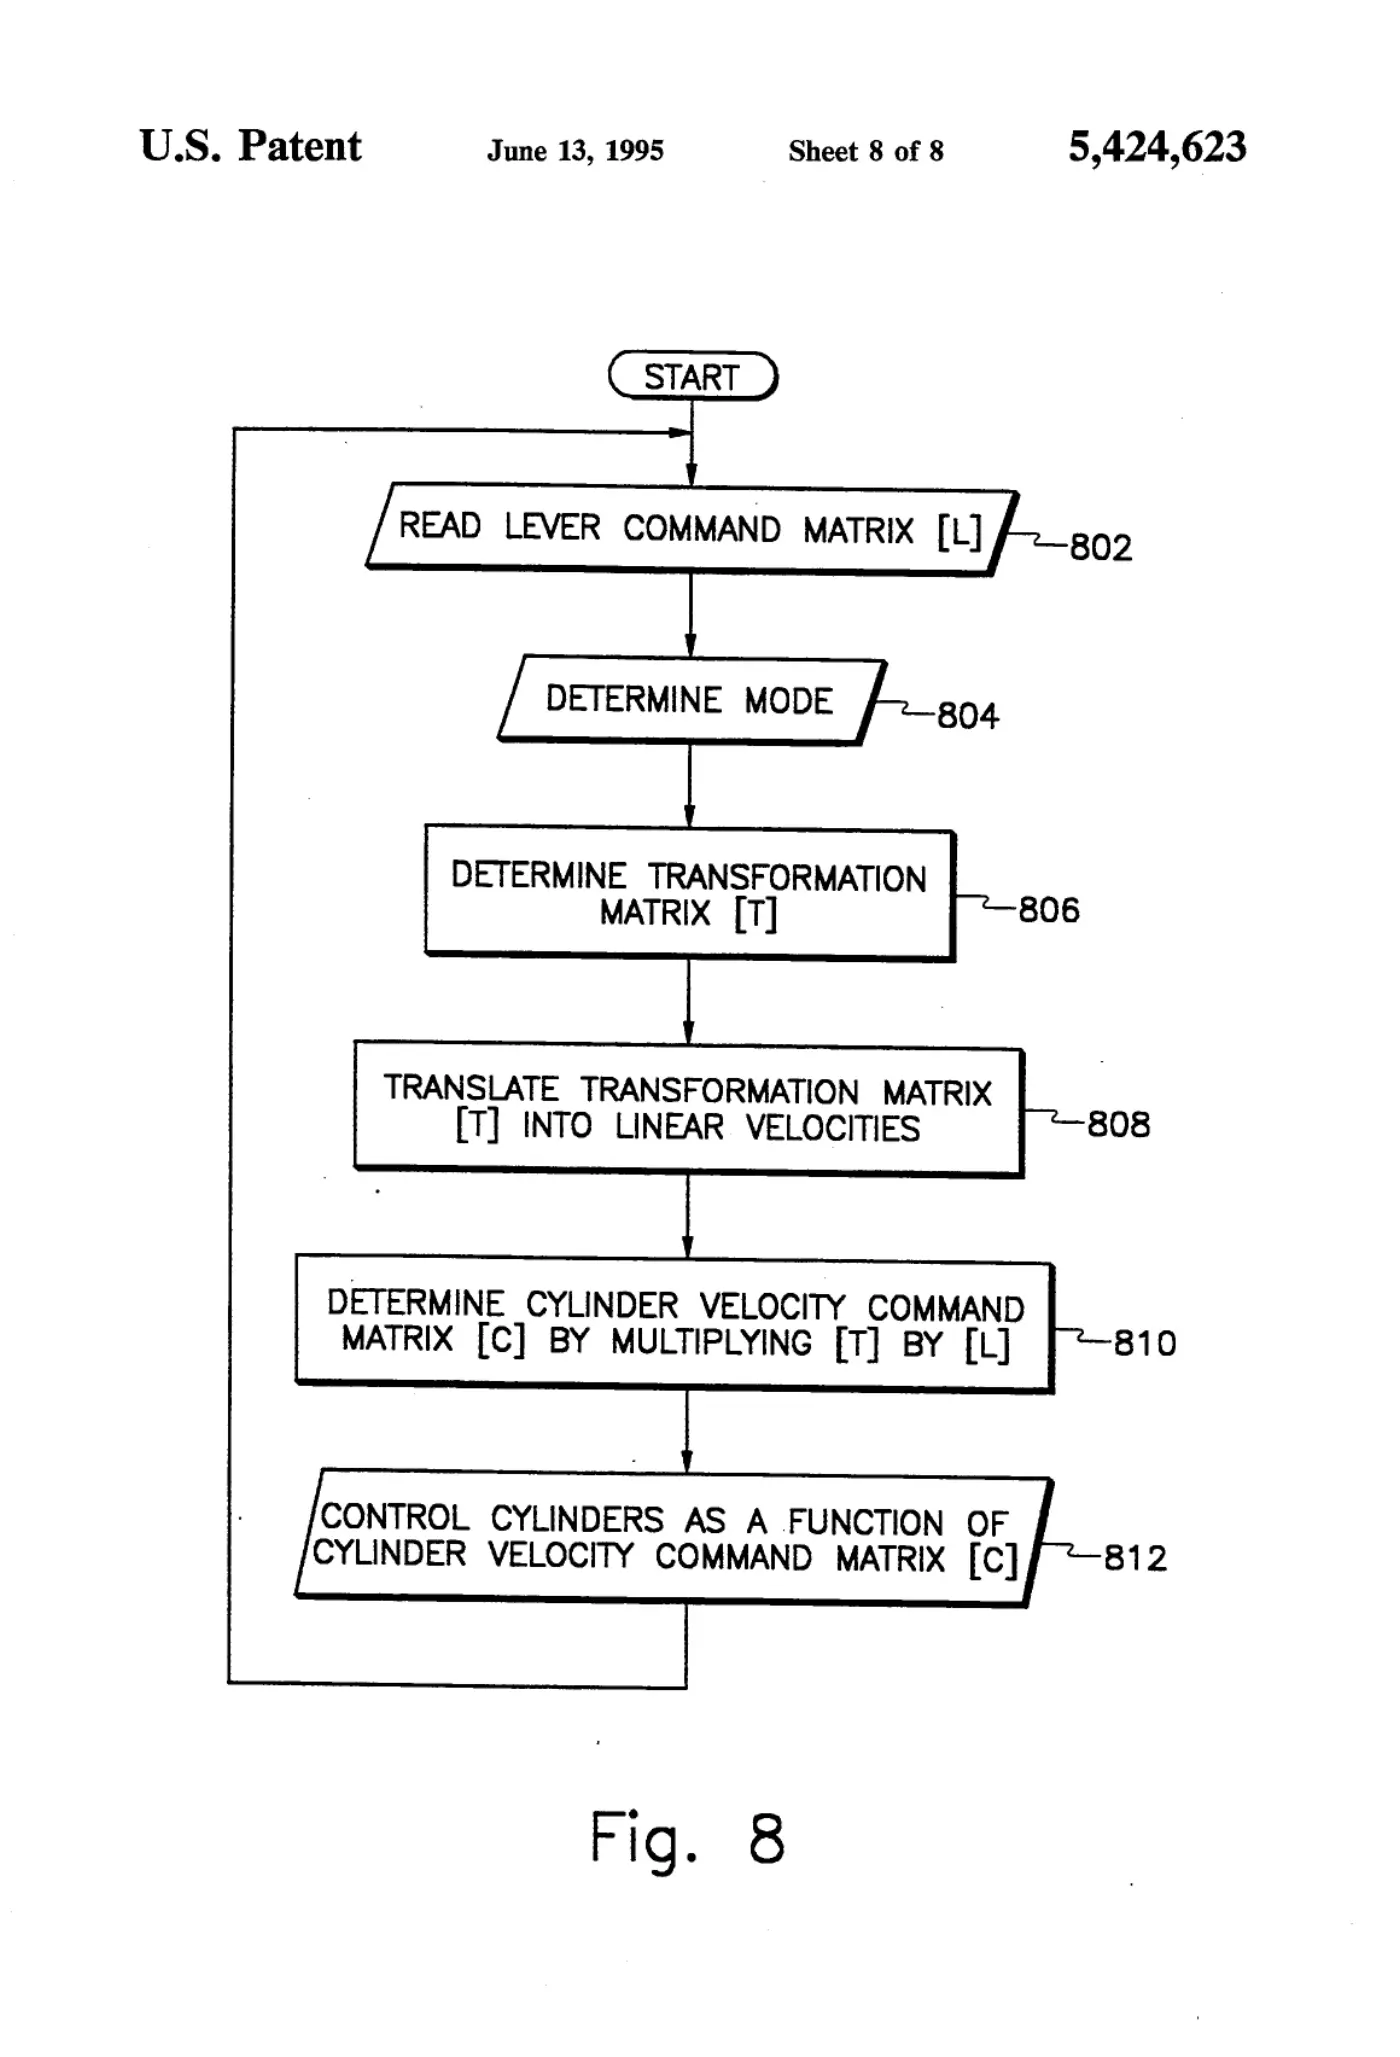
[0008]Sheet 8.
Publication information
Citation
OpenTechnical Publication OT-2026-000003308, “Coordinated control for a work implement,” published September 15, 2026 at 20:06:50 UTC, https://opentechnical.org/p/OT-2026-000003308.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.