OT-2026-000003319
Method and system for loading rigid sheet material into shipping containers at a work station and end effector for use therein
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003319
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- PEARSON THOMAS E
- Assignee
- FORD MOTOR CO
- Original source
- US-5387068-A, the United States Patent and Trademark Office, 7 February 1995
- Document SHA-256
- 24971a14b71a5213c110efe9903df462b9680089189f09828ef2a518f566d651
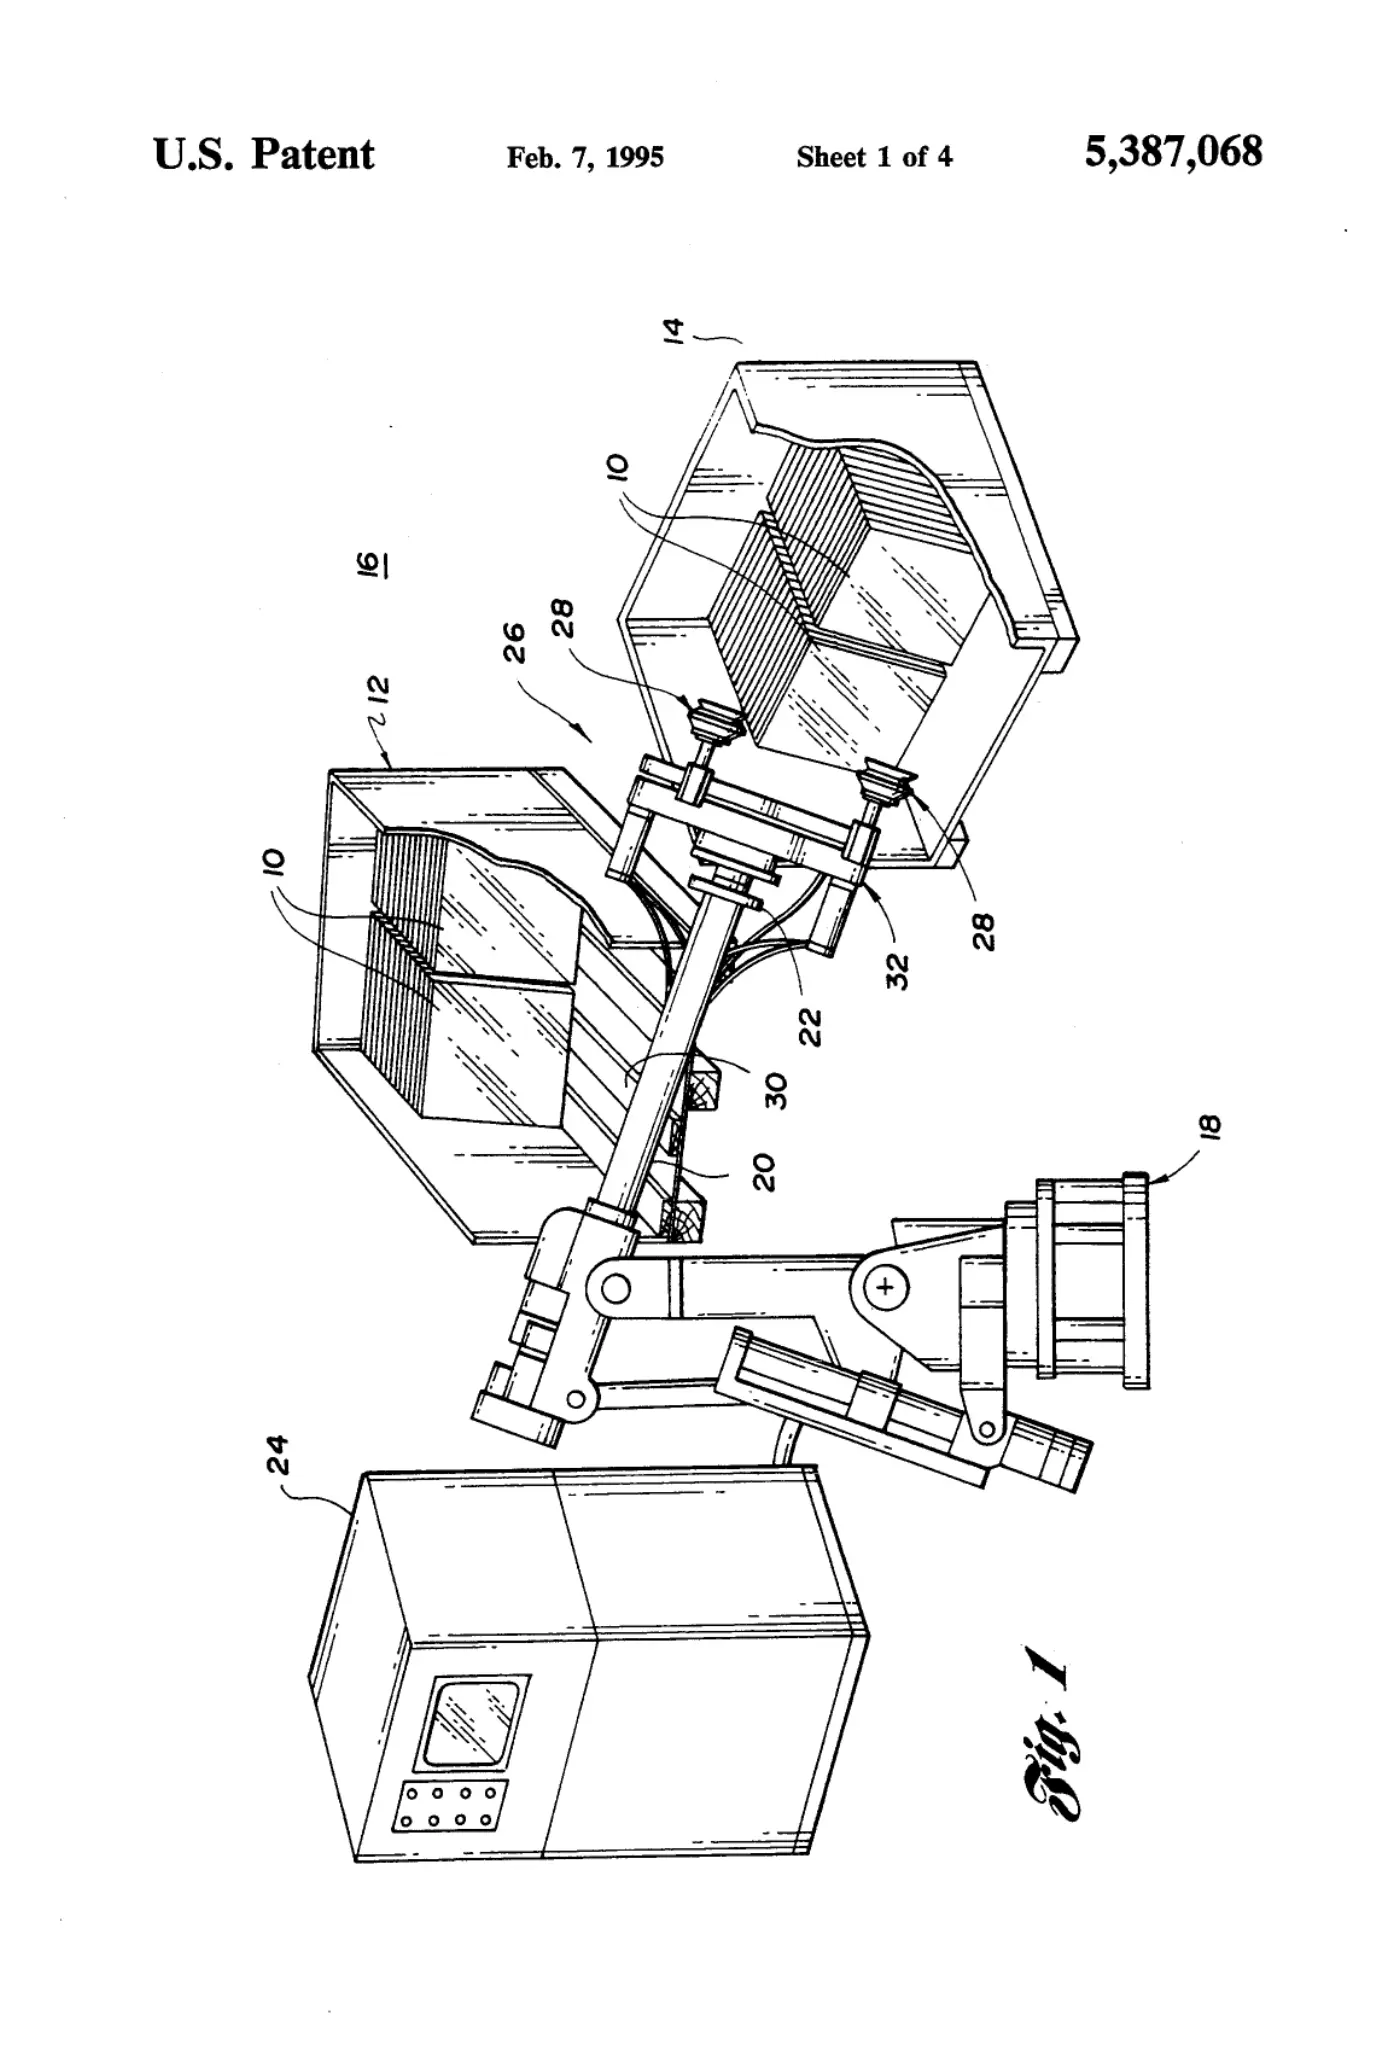
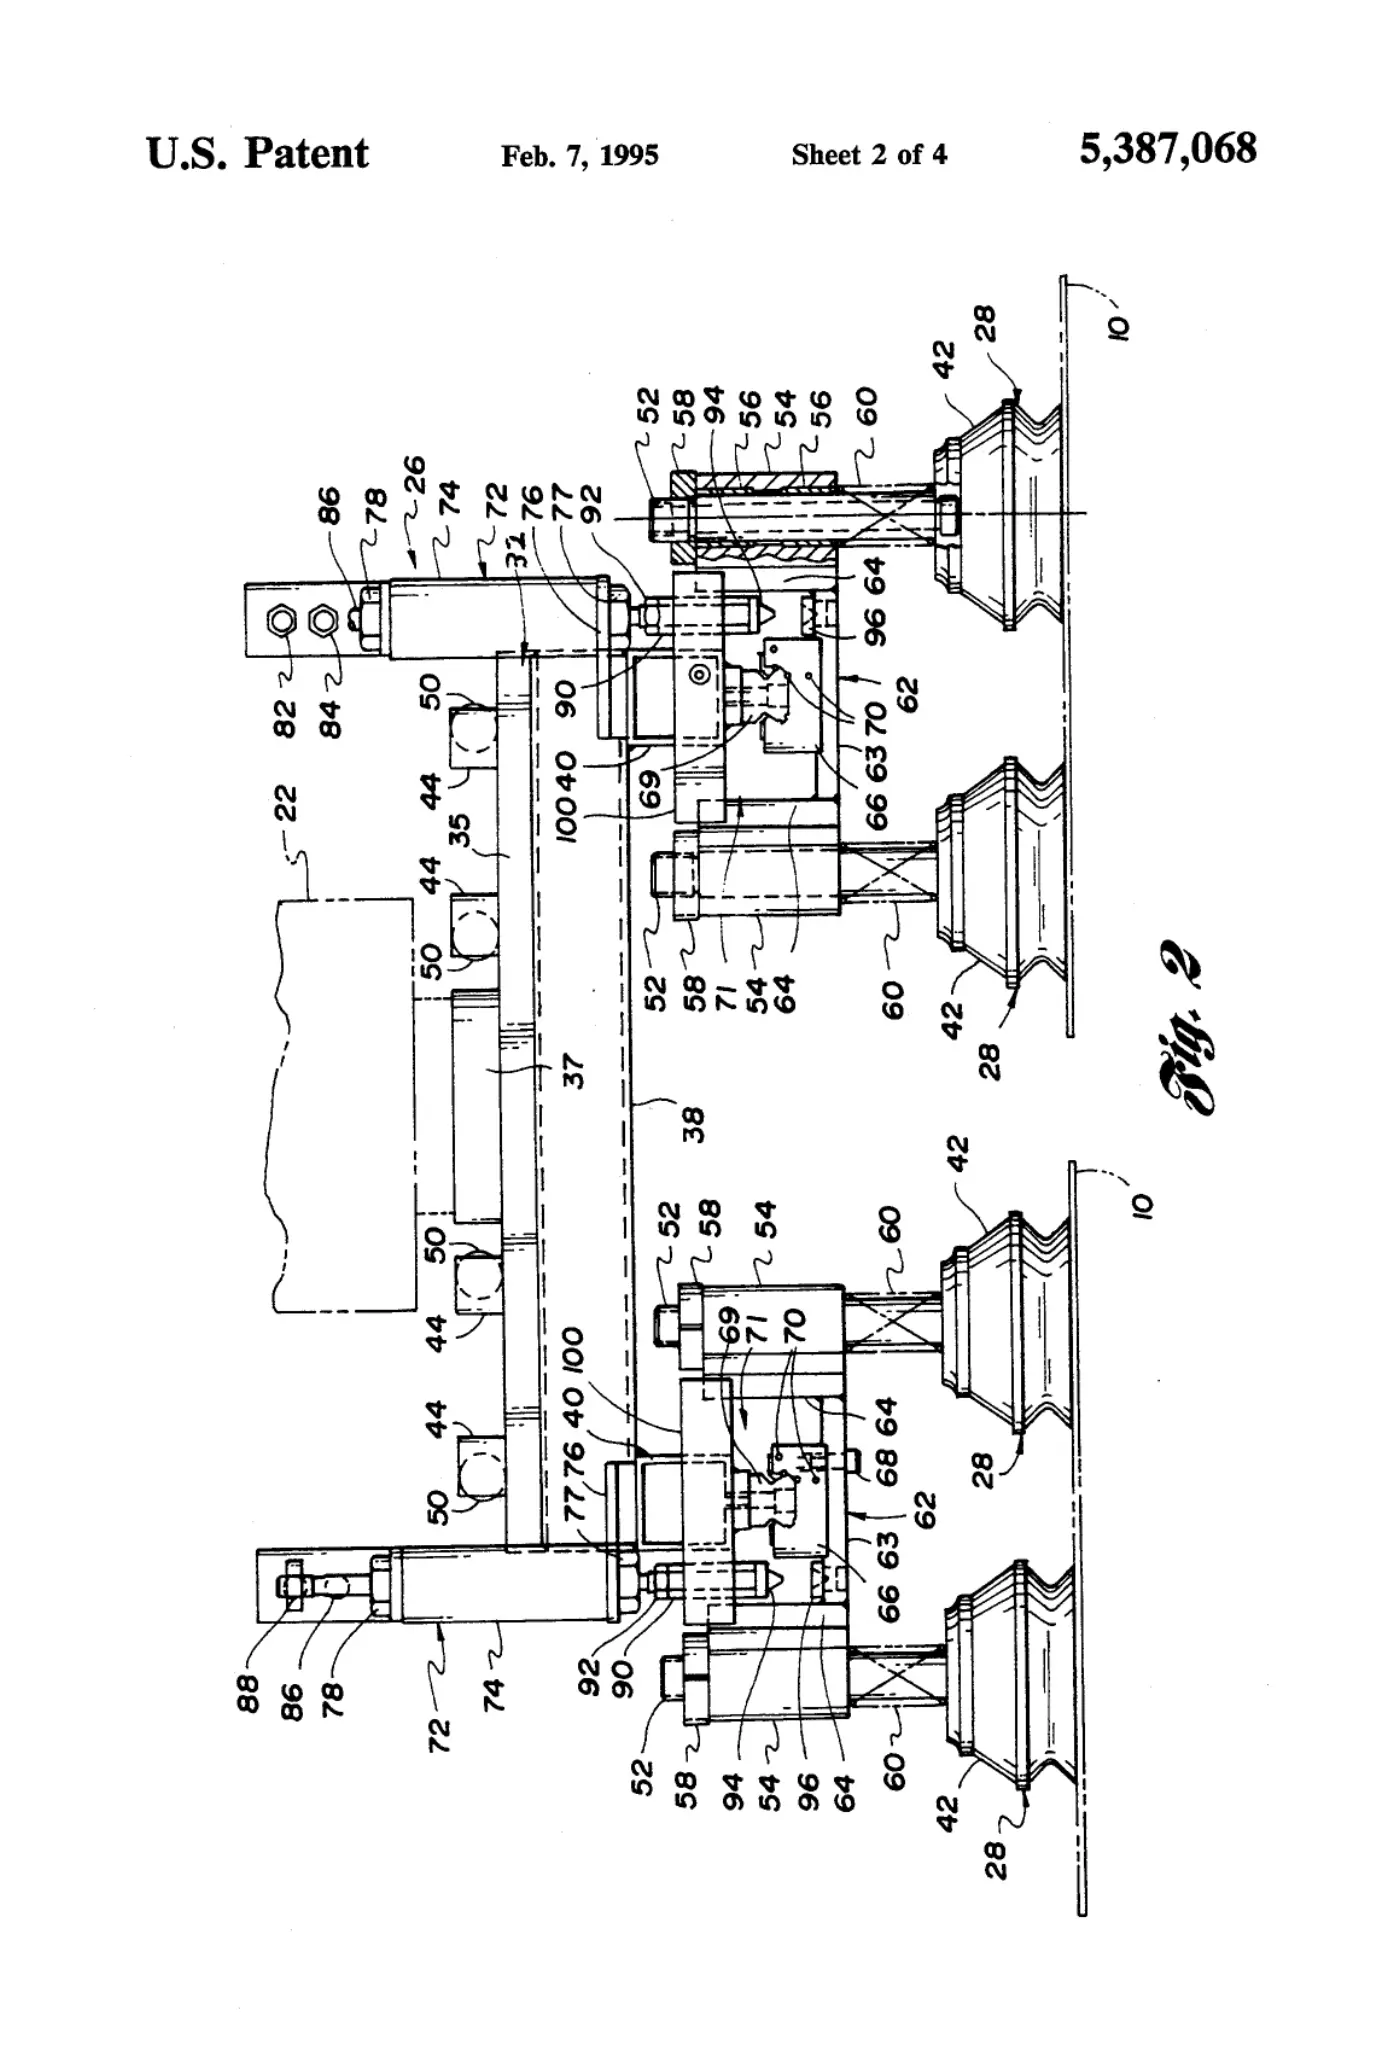
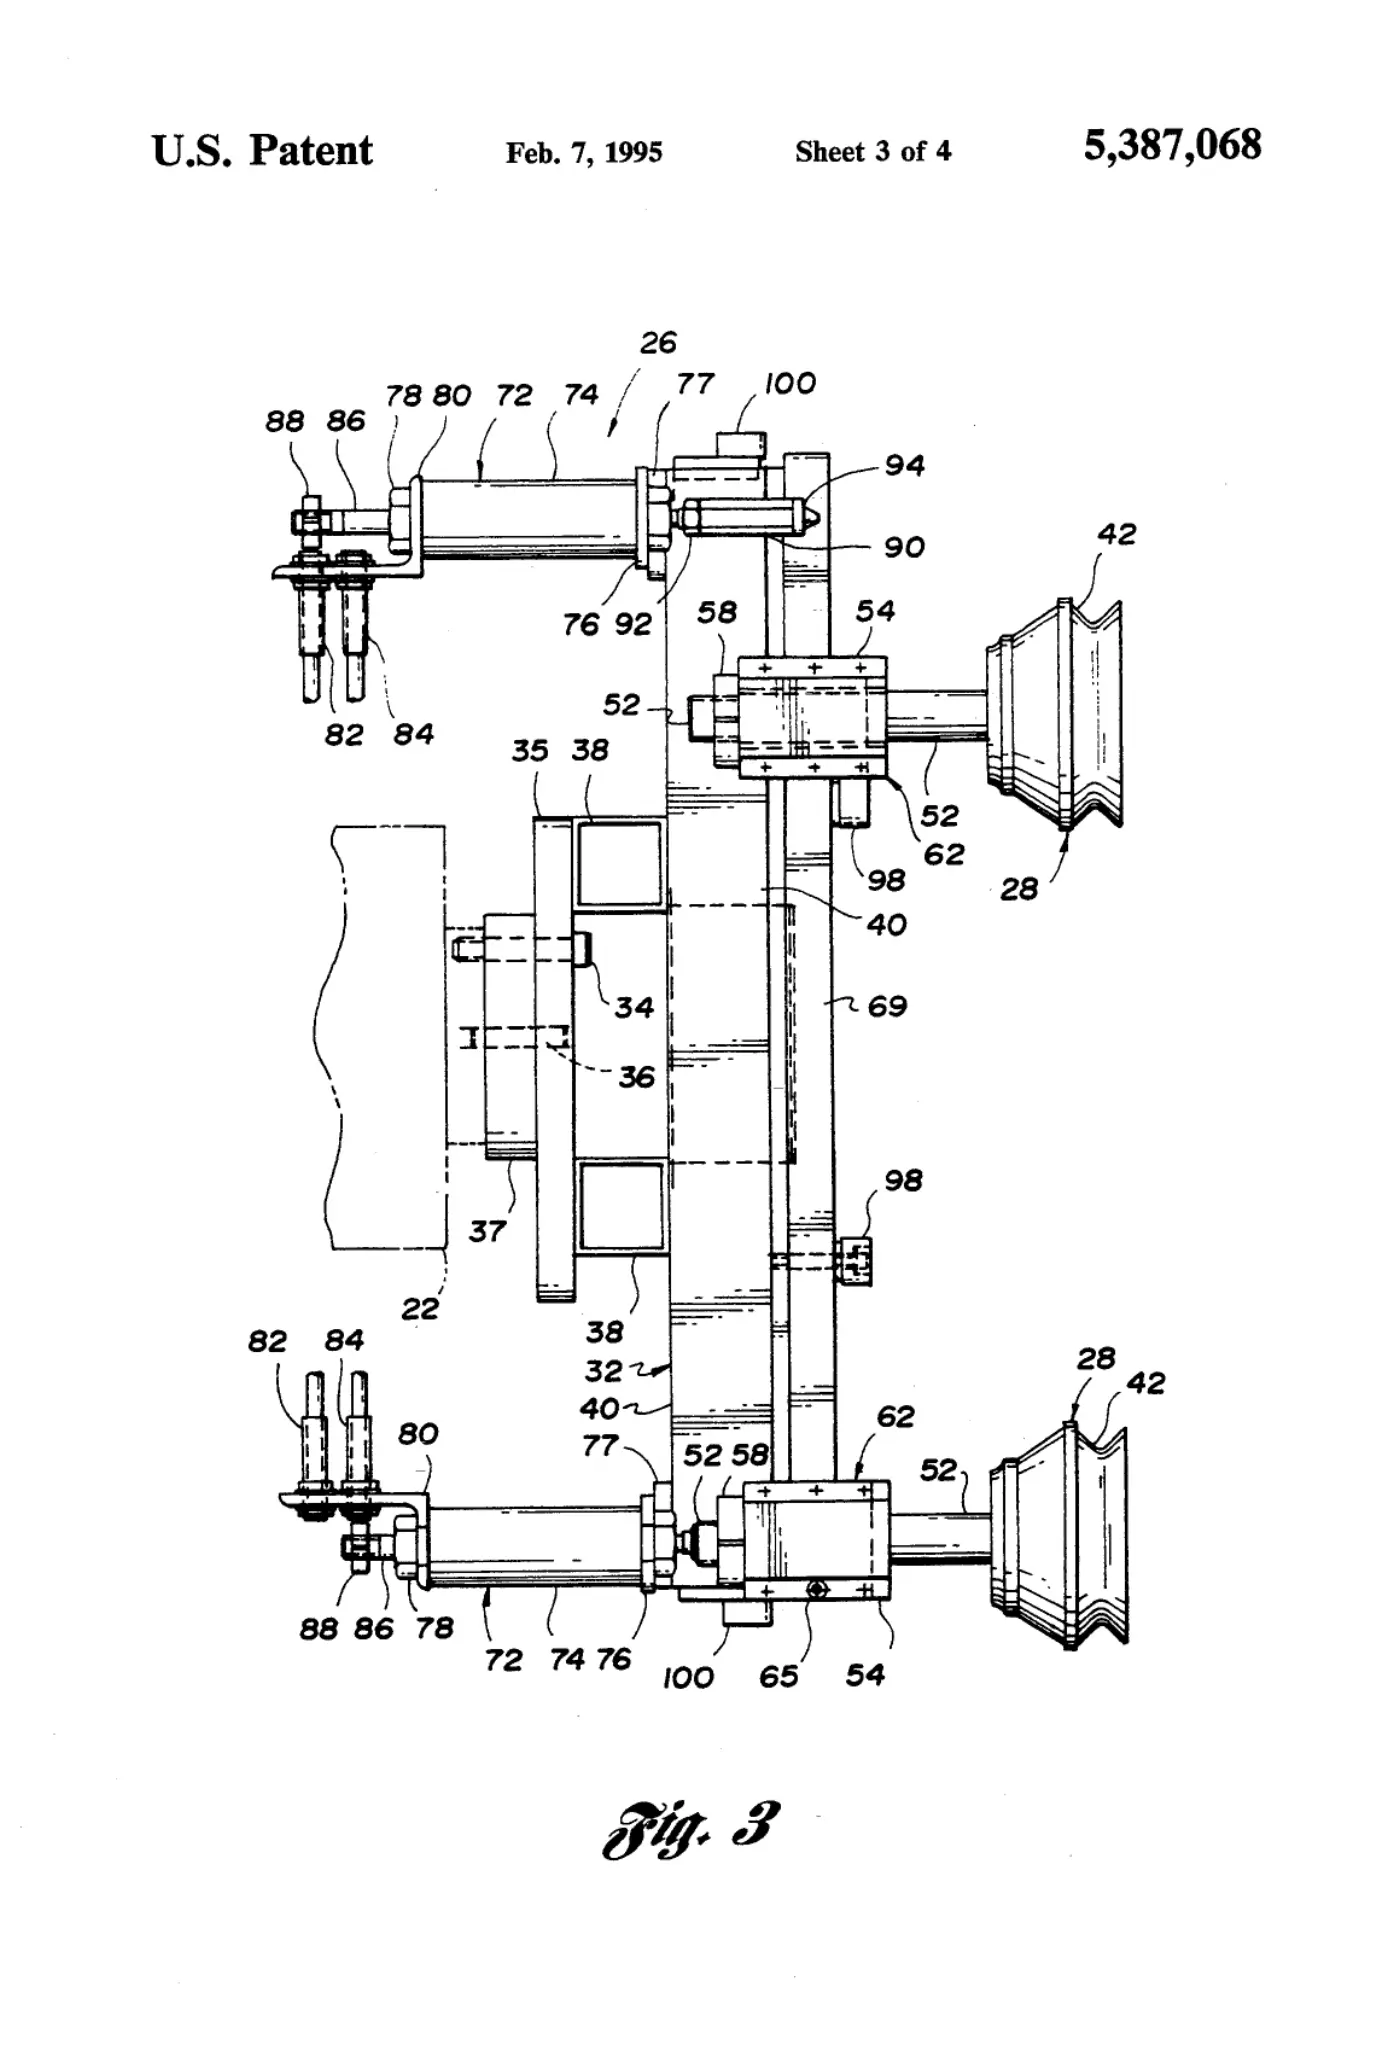
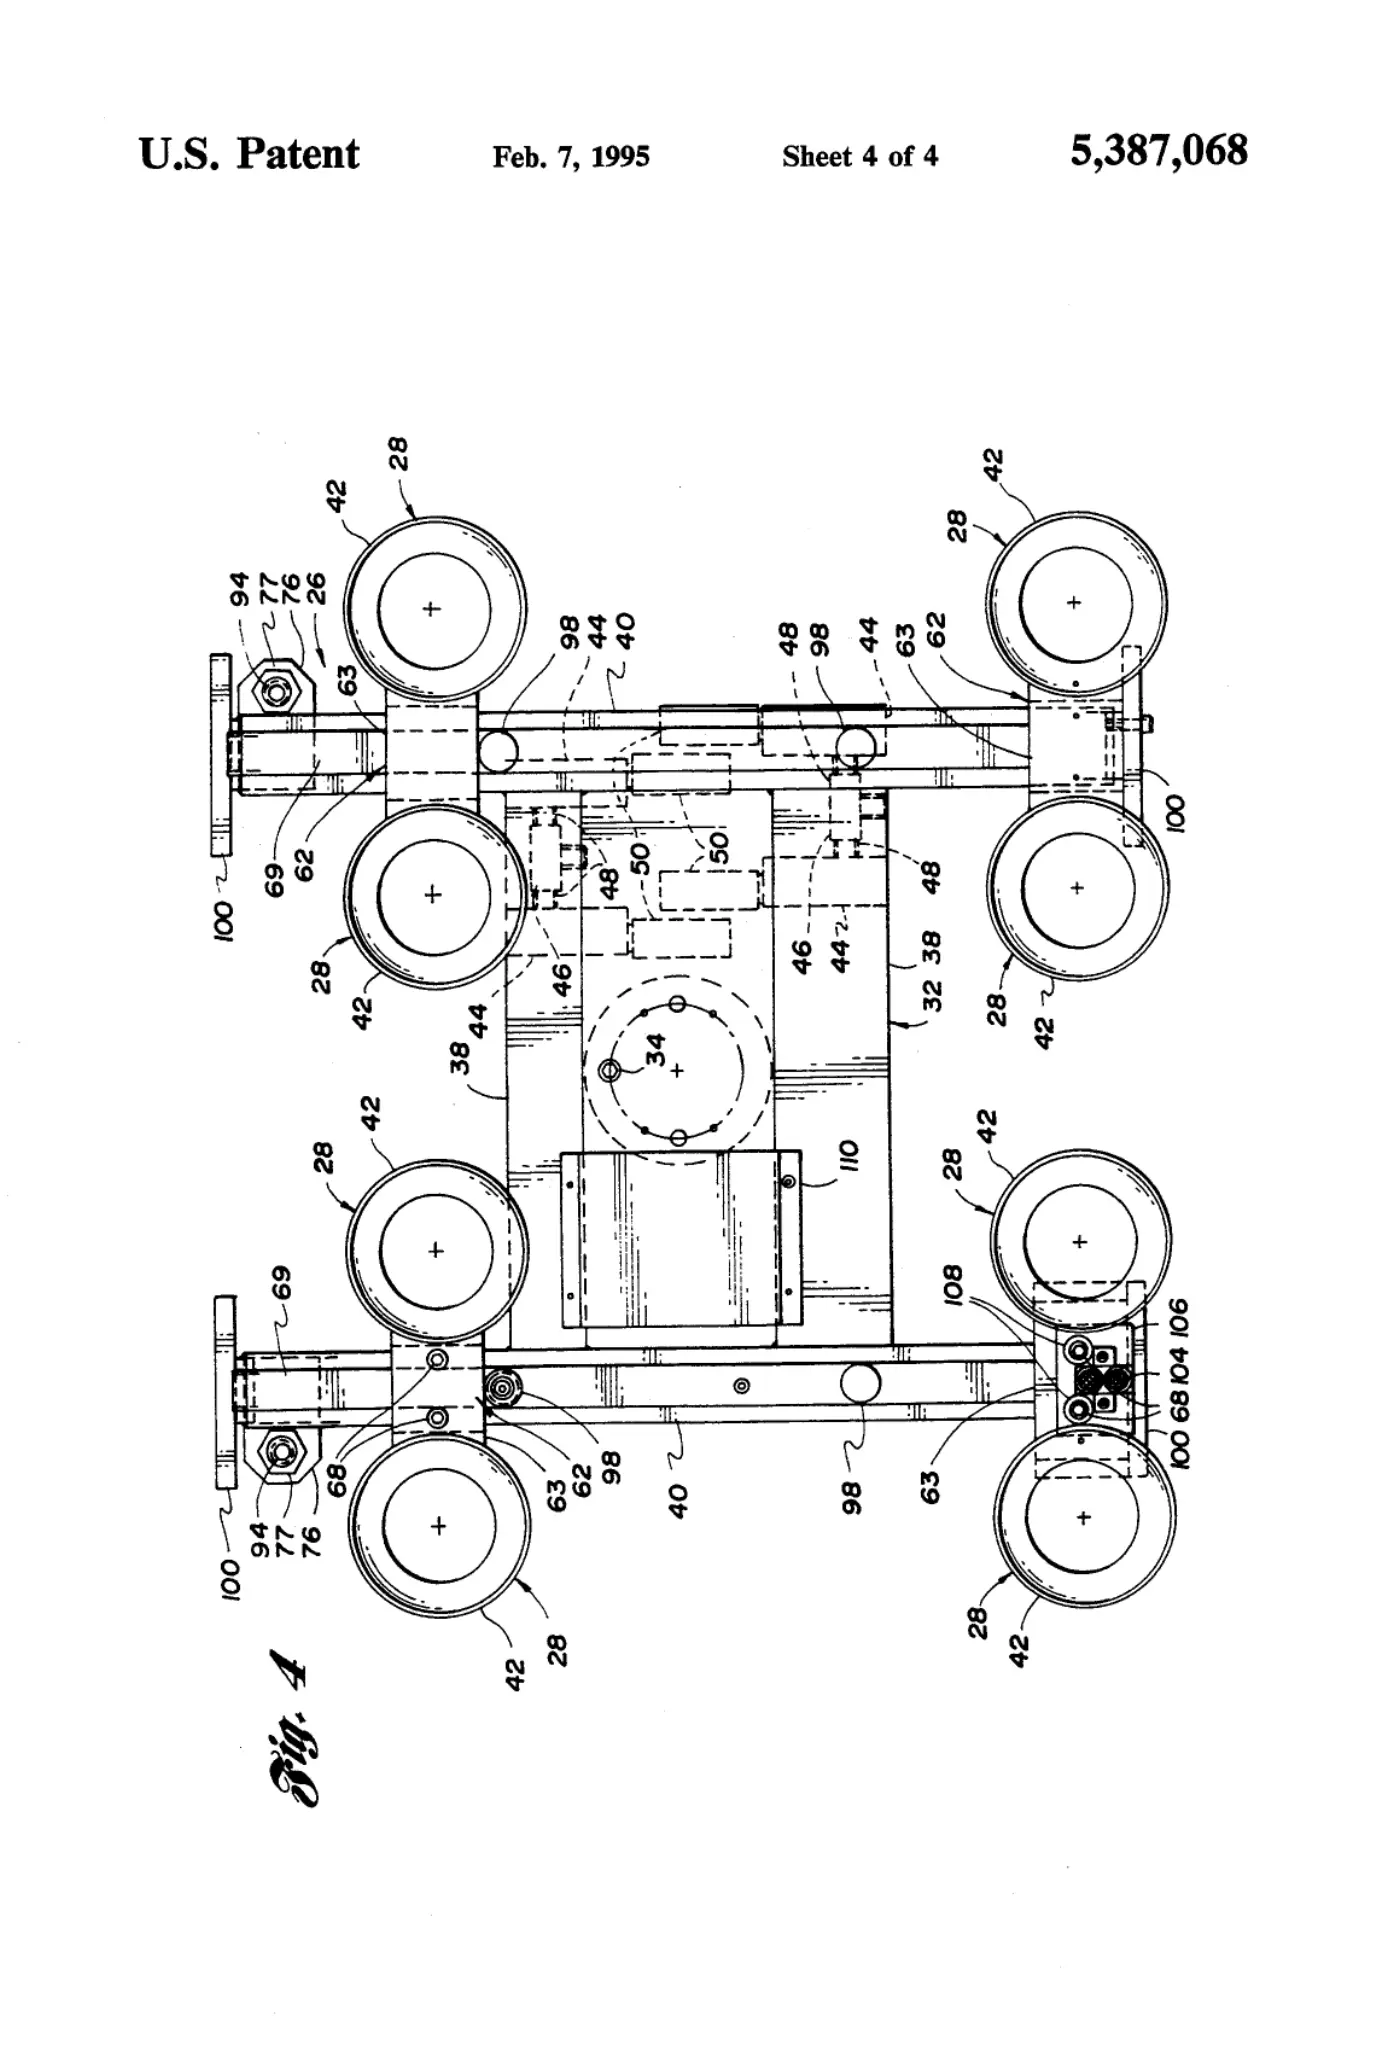
A robotic end effector adapted to be mounted at the end of an arm of a program-controlled robot is capable of providing compliance within a vertical plane. A method and system utilizing the end effector pick-up flat or curved glass panels from glass racks and place the glass panels into irregularly-shaped wooden crates. Due to the compliance provided by the end effector, the system allows essentially perfect piece-to-piece vertical edge-of-glass alignment during the packaging process so as to eliminate glass etching/scratching. The end effector includes a base frame on which compliance devices in the form of linear bearing systems support a number of material handling devices in the form of suction devices. Selected ones of the compliance devices can be locked out under the control of a controller for the robot. Each suction device includes a spring-biased suction cup to also provide compliance in a direction substantially normal to the compliance provided in the vertical plane.
Abstract
A robotic end effector adapted to be mounted at the end of an arm of a program-controlled robot is capable of providing compliance within a vertical plane. A method and system utilizing the end effector pick-up flat or curved glass panels from glass racks and place the glass panels into irregularly-shaped wooden crates. Due to the compliance provided by the end effector, the system allows essentially perfect piece-to-piece vertical edge-of-glass alignment during the packaging process so as to eliminate glass etching/scratching. The end effector includes a base frame on which compliance devices in the form of linear bearing systems support a number of material handling devices in the form of suction devices. Selected ones of the compliance devices can be locked out under the control of a controller for the robot. Each suction device includes a spring-biased suction cup to also provide compliance in a direction substantially normal to the compliance provided in the vertical plane.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
Publication information
Citation
OpenTechnical Publication OT-2026-000003319, “Method and system for loading rigid sheet material into shipping containers at a work station and end effector for use therein,” published September 15, 2026 at 20:09:00 UTC, https://opentechnical.org/p/OT-2026-000003319.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.