OT-2026-000003321
Multi-variable control of multi-degree of freedom linkages
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003321
- Classification
- Industrial Motion & Power Transmission › Fluid Power
- Assignee
- CATERPILLAR INC
- Original source
- US-5383390-A, the United States Patent and Trademark Office, 24 January 1995
- Document SHA-256
- dabb63991e423984ee3bb7db7324c8251d4a048b3c7821ea44c8ef24bcfe834f
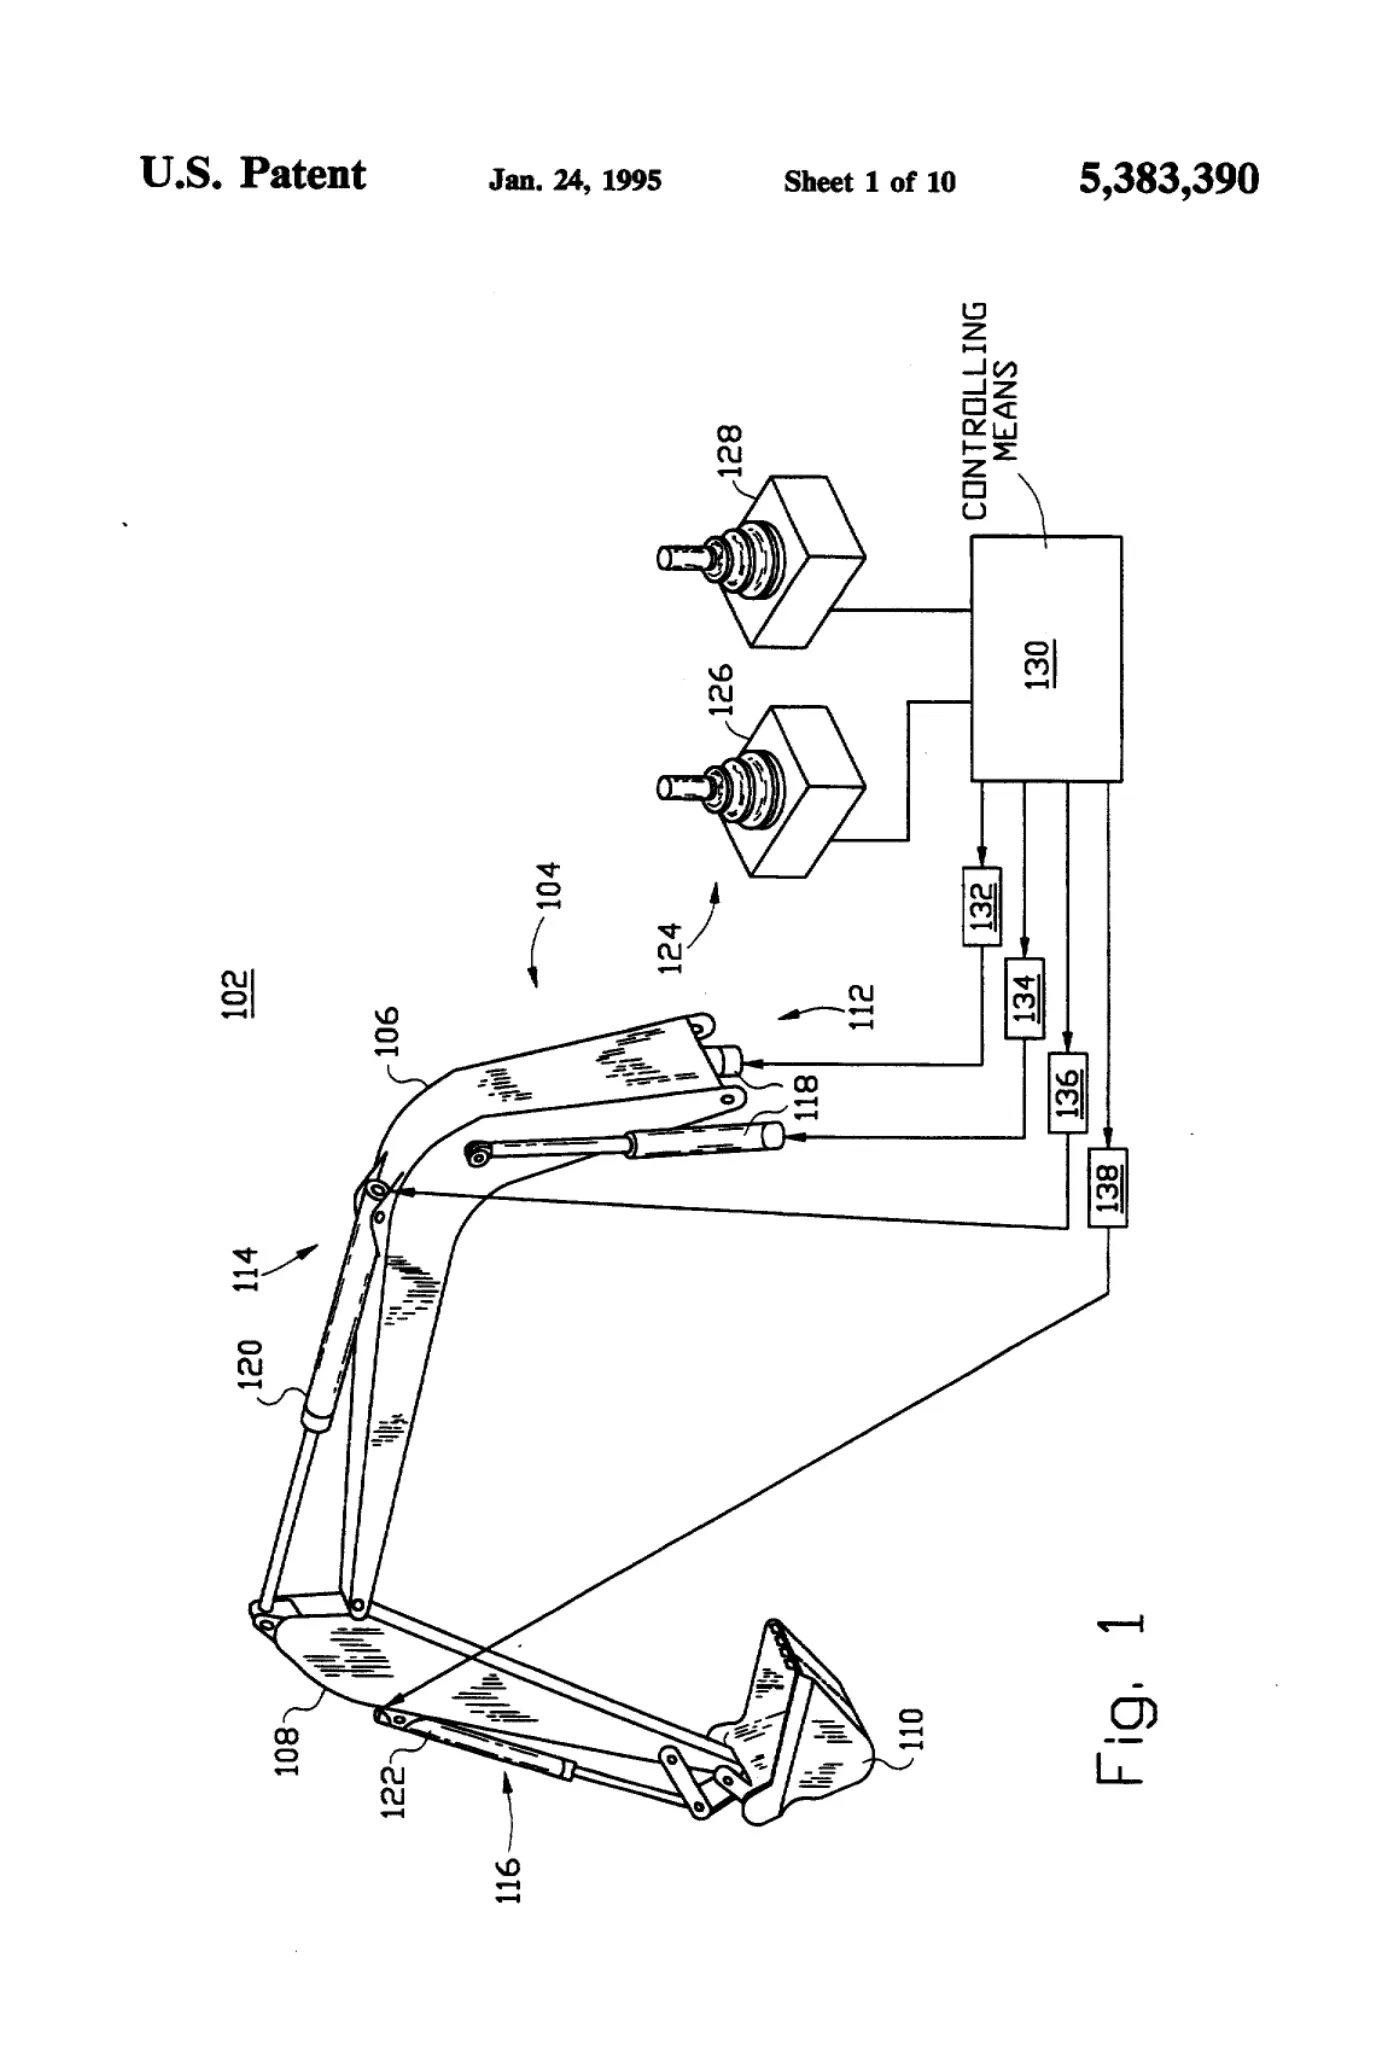
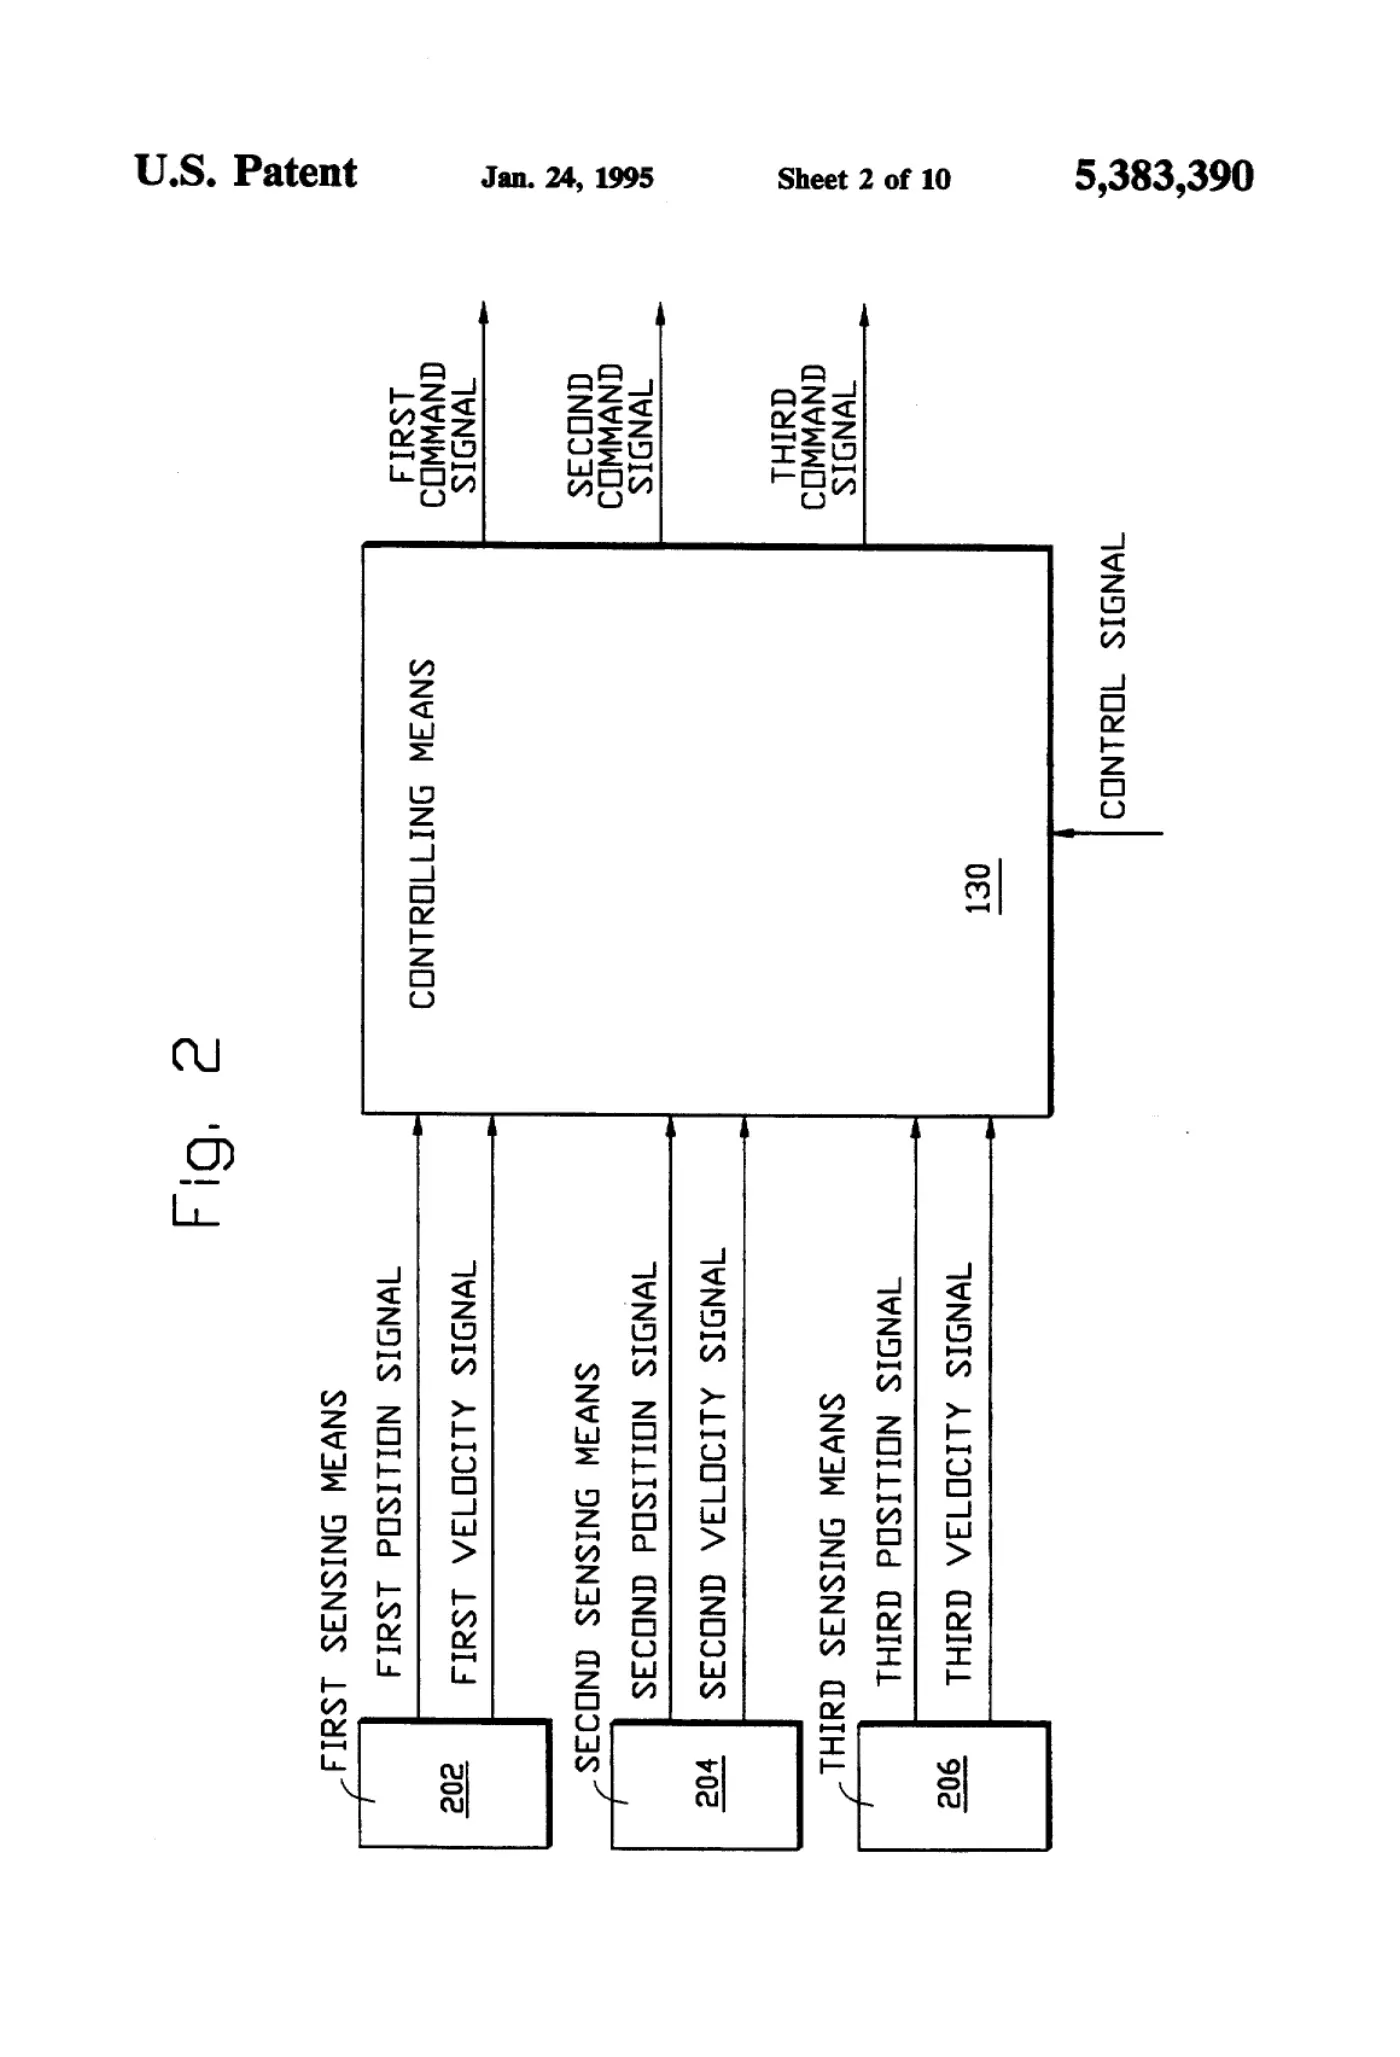
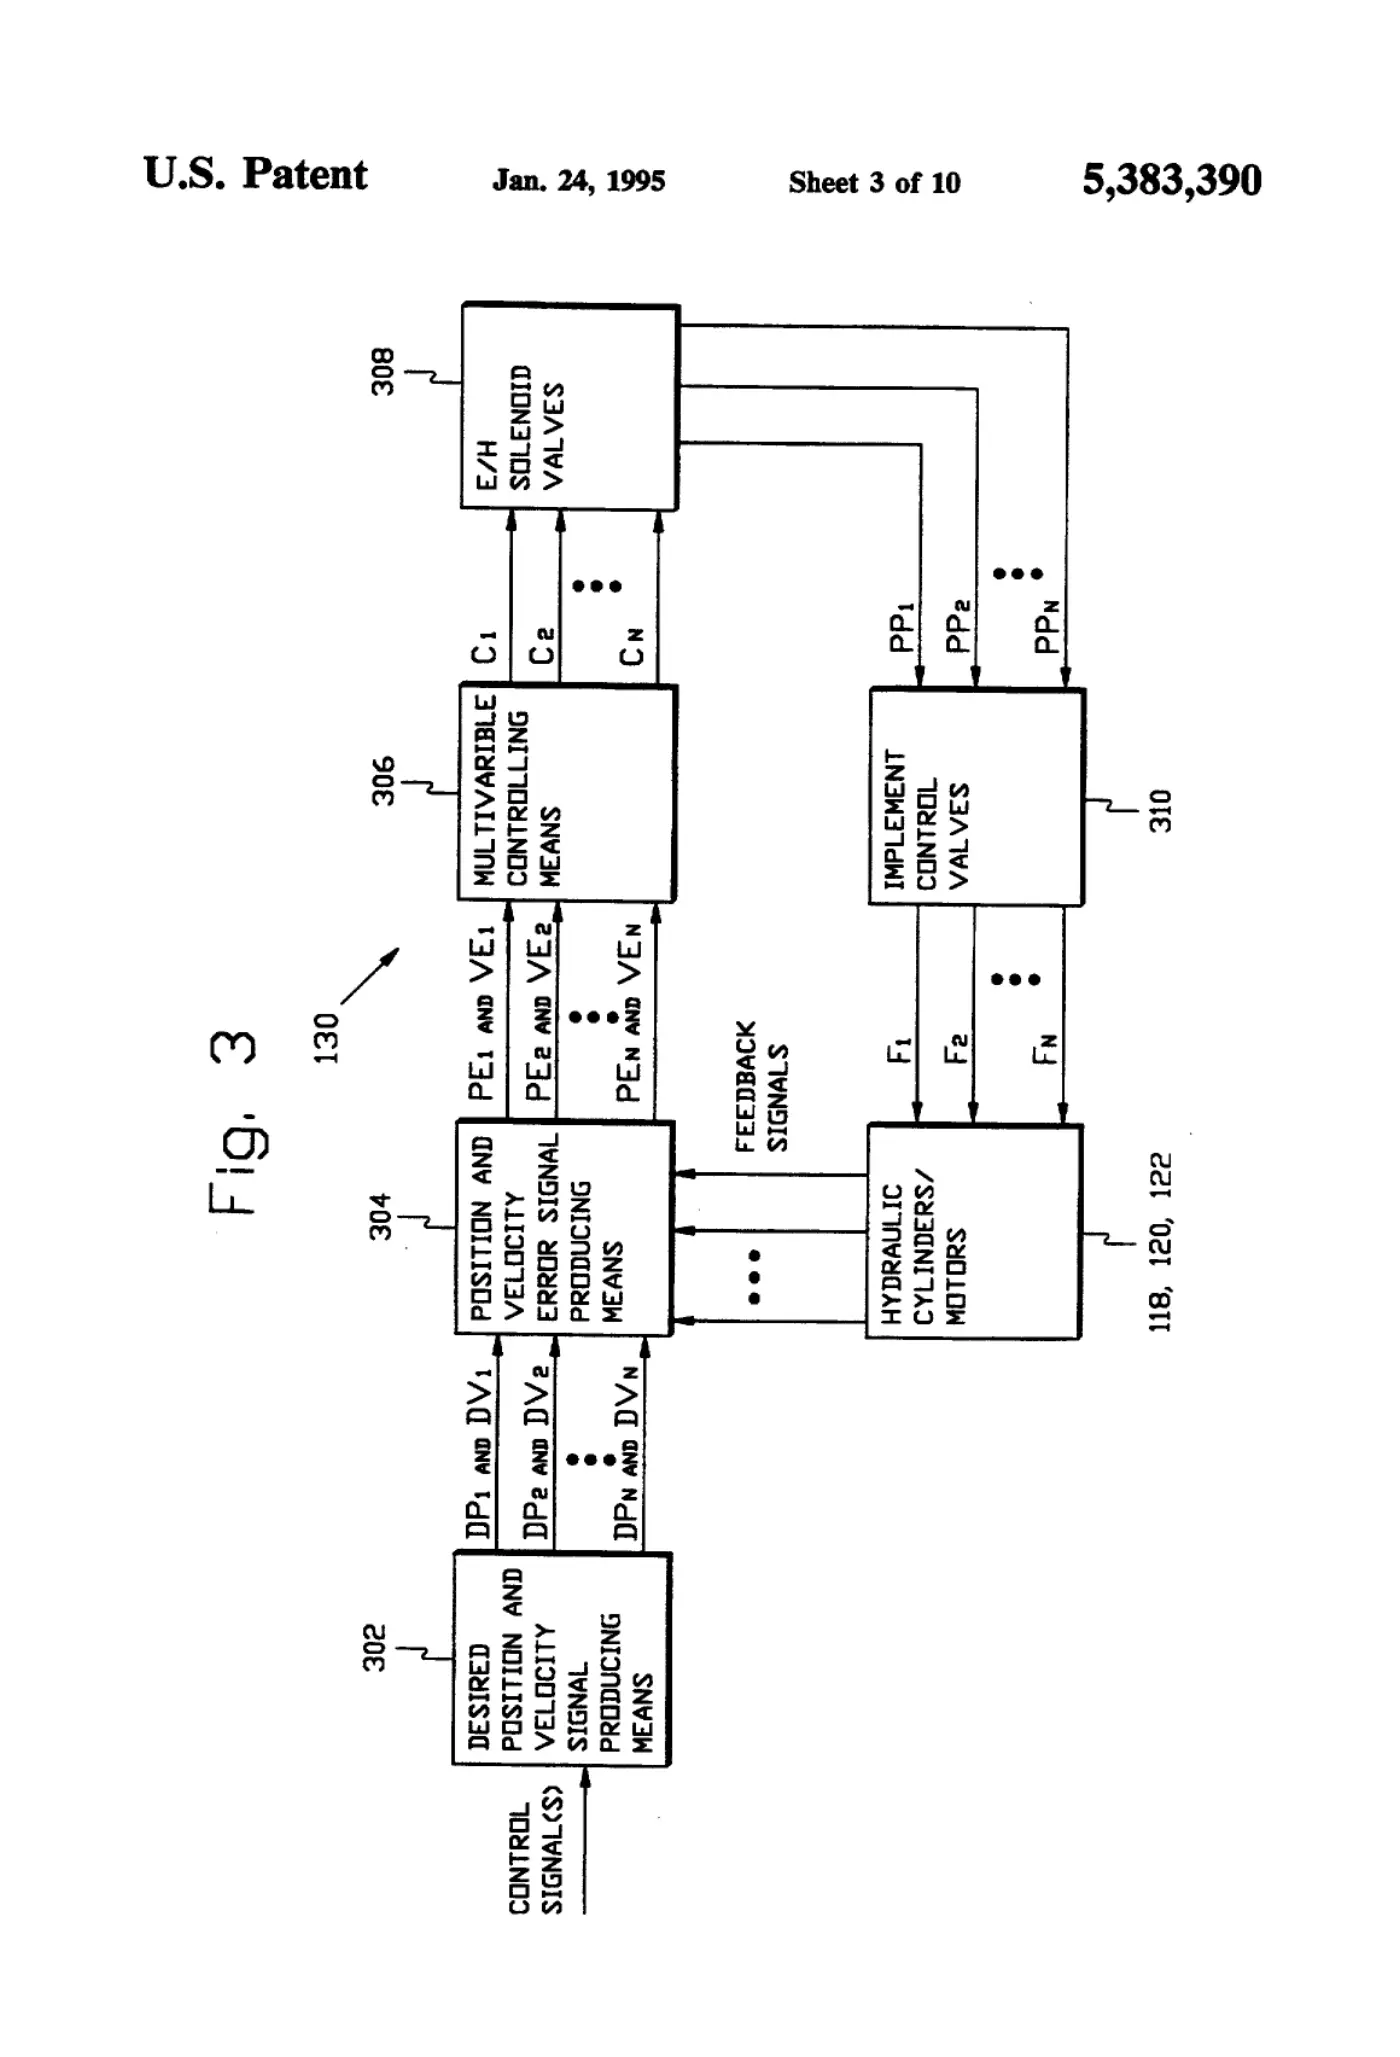
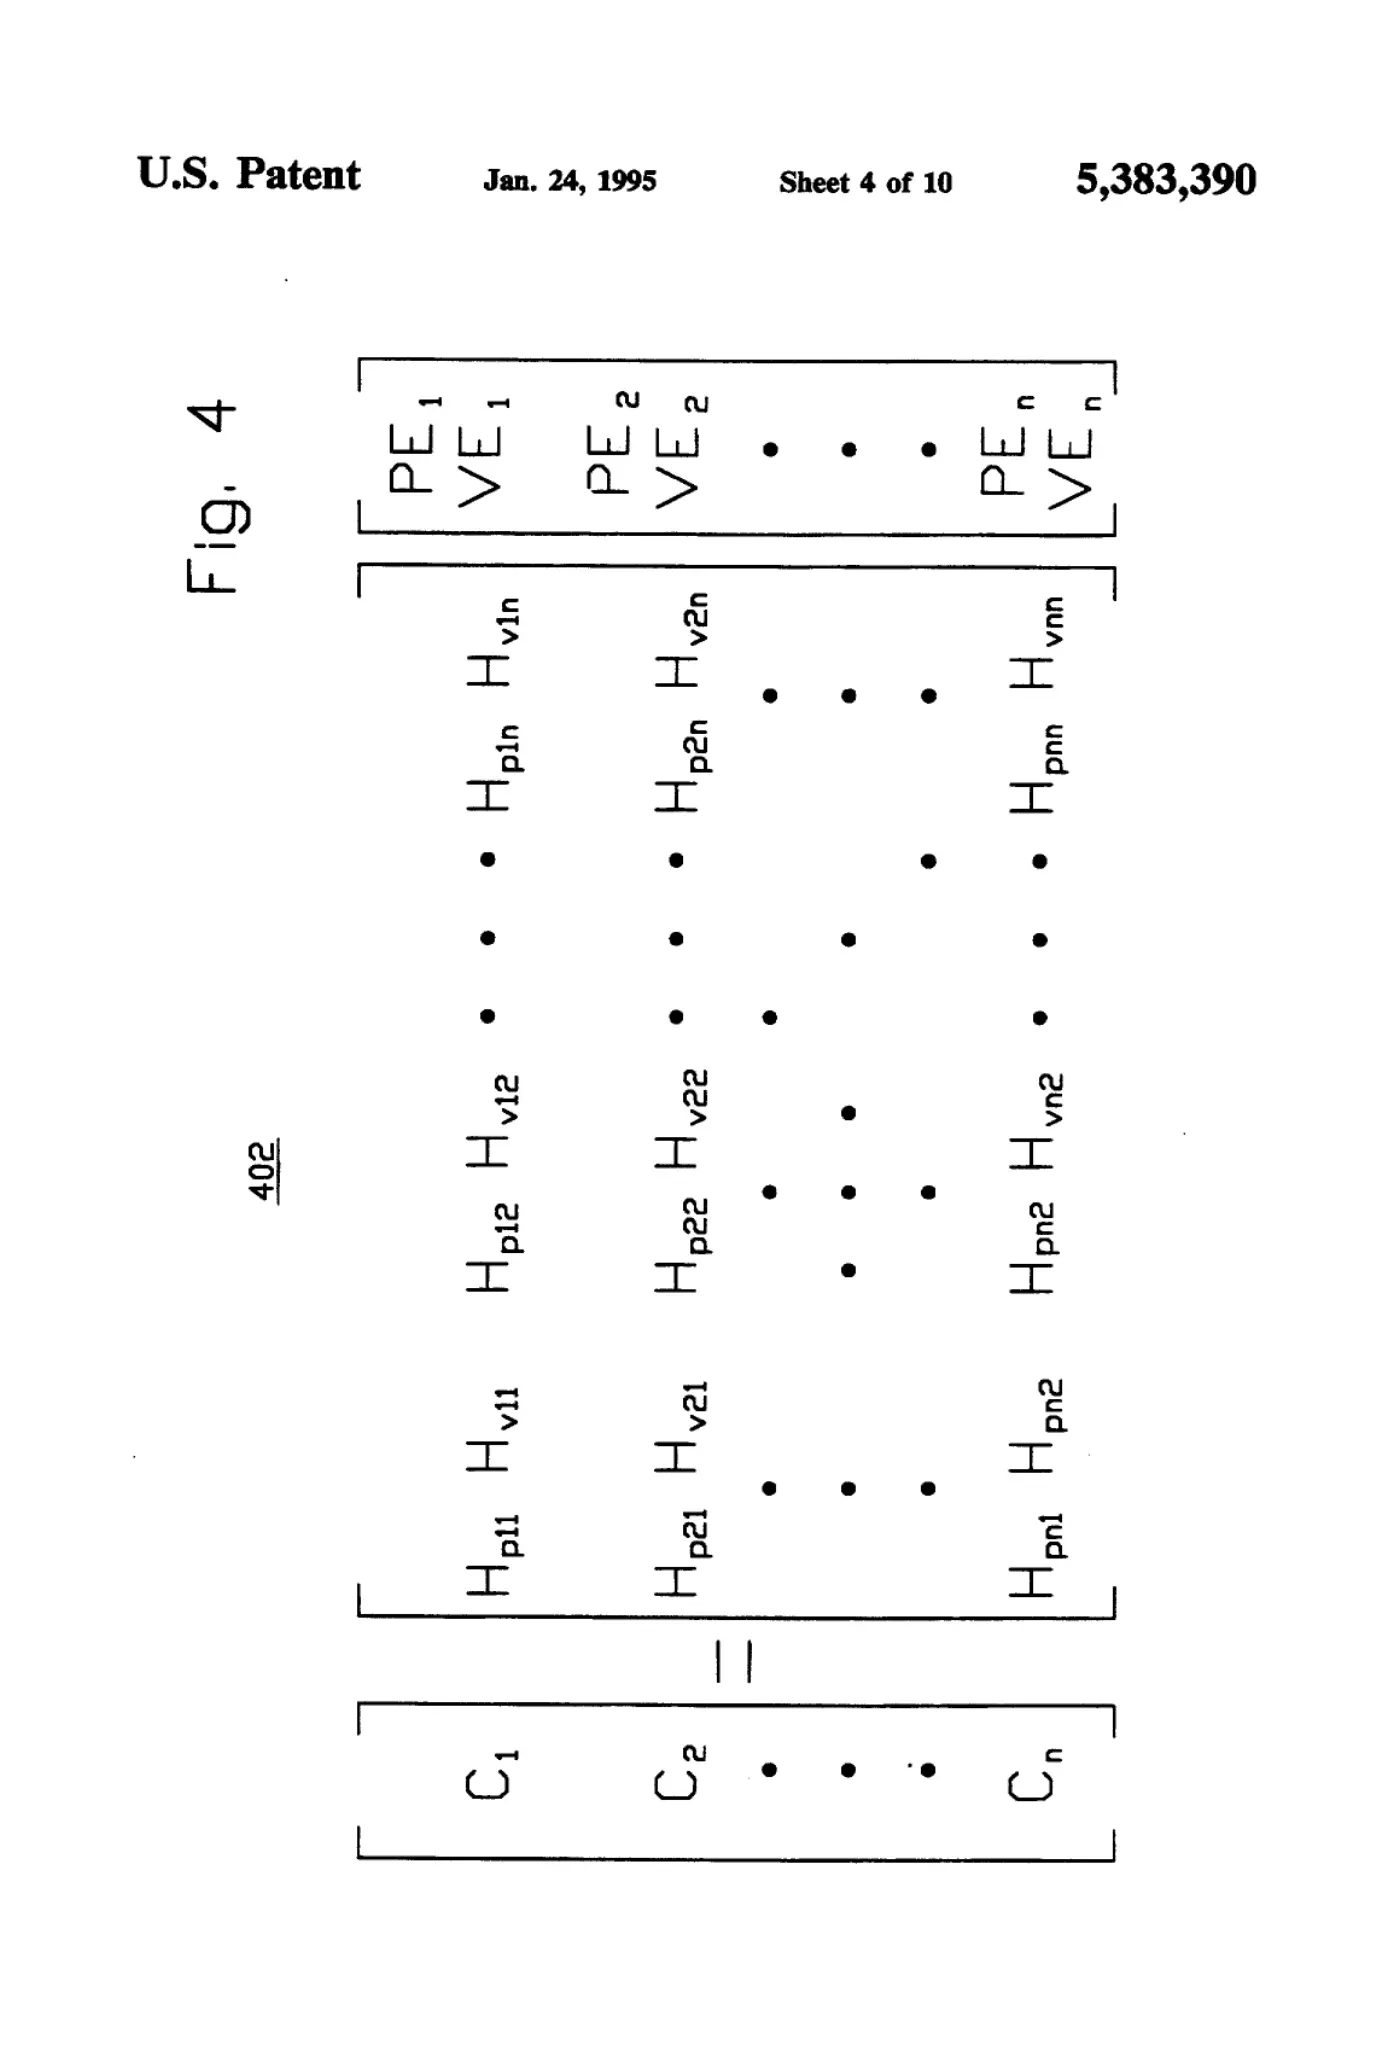
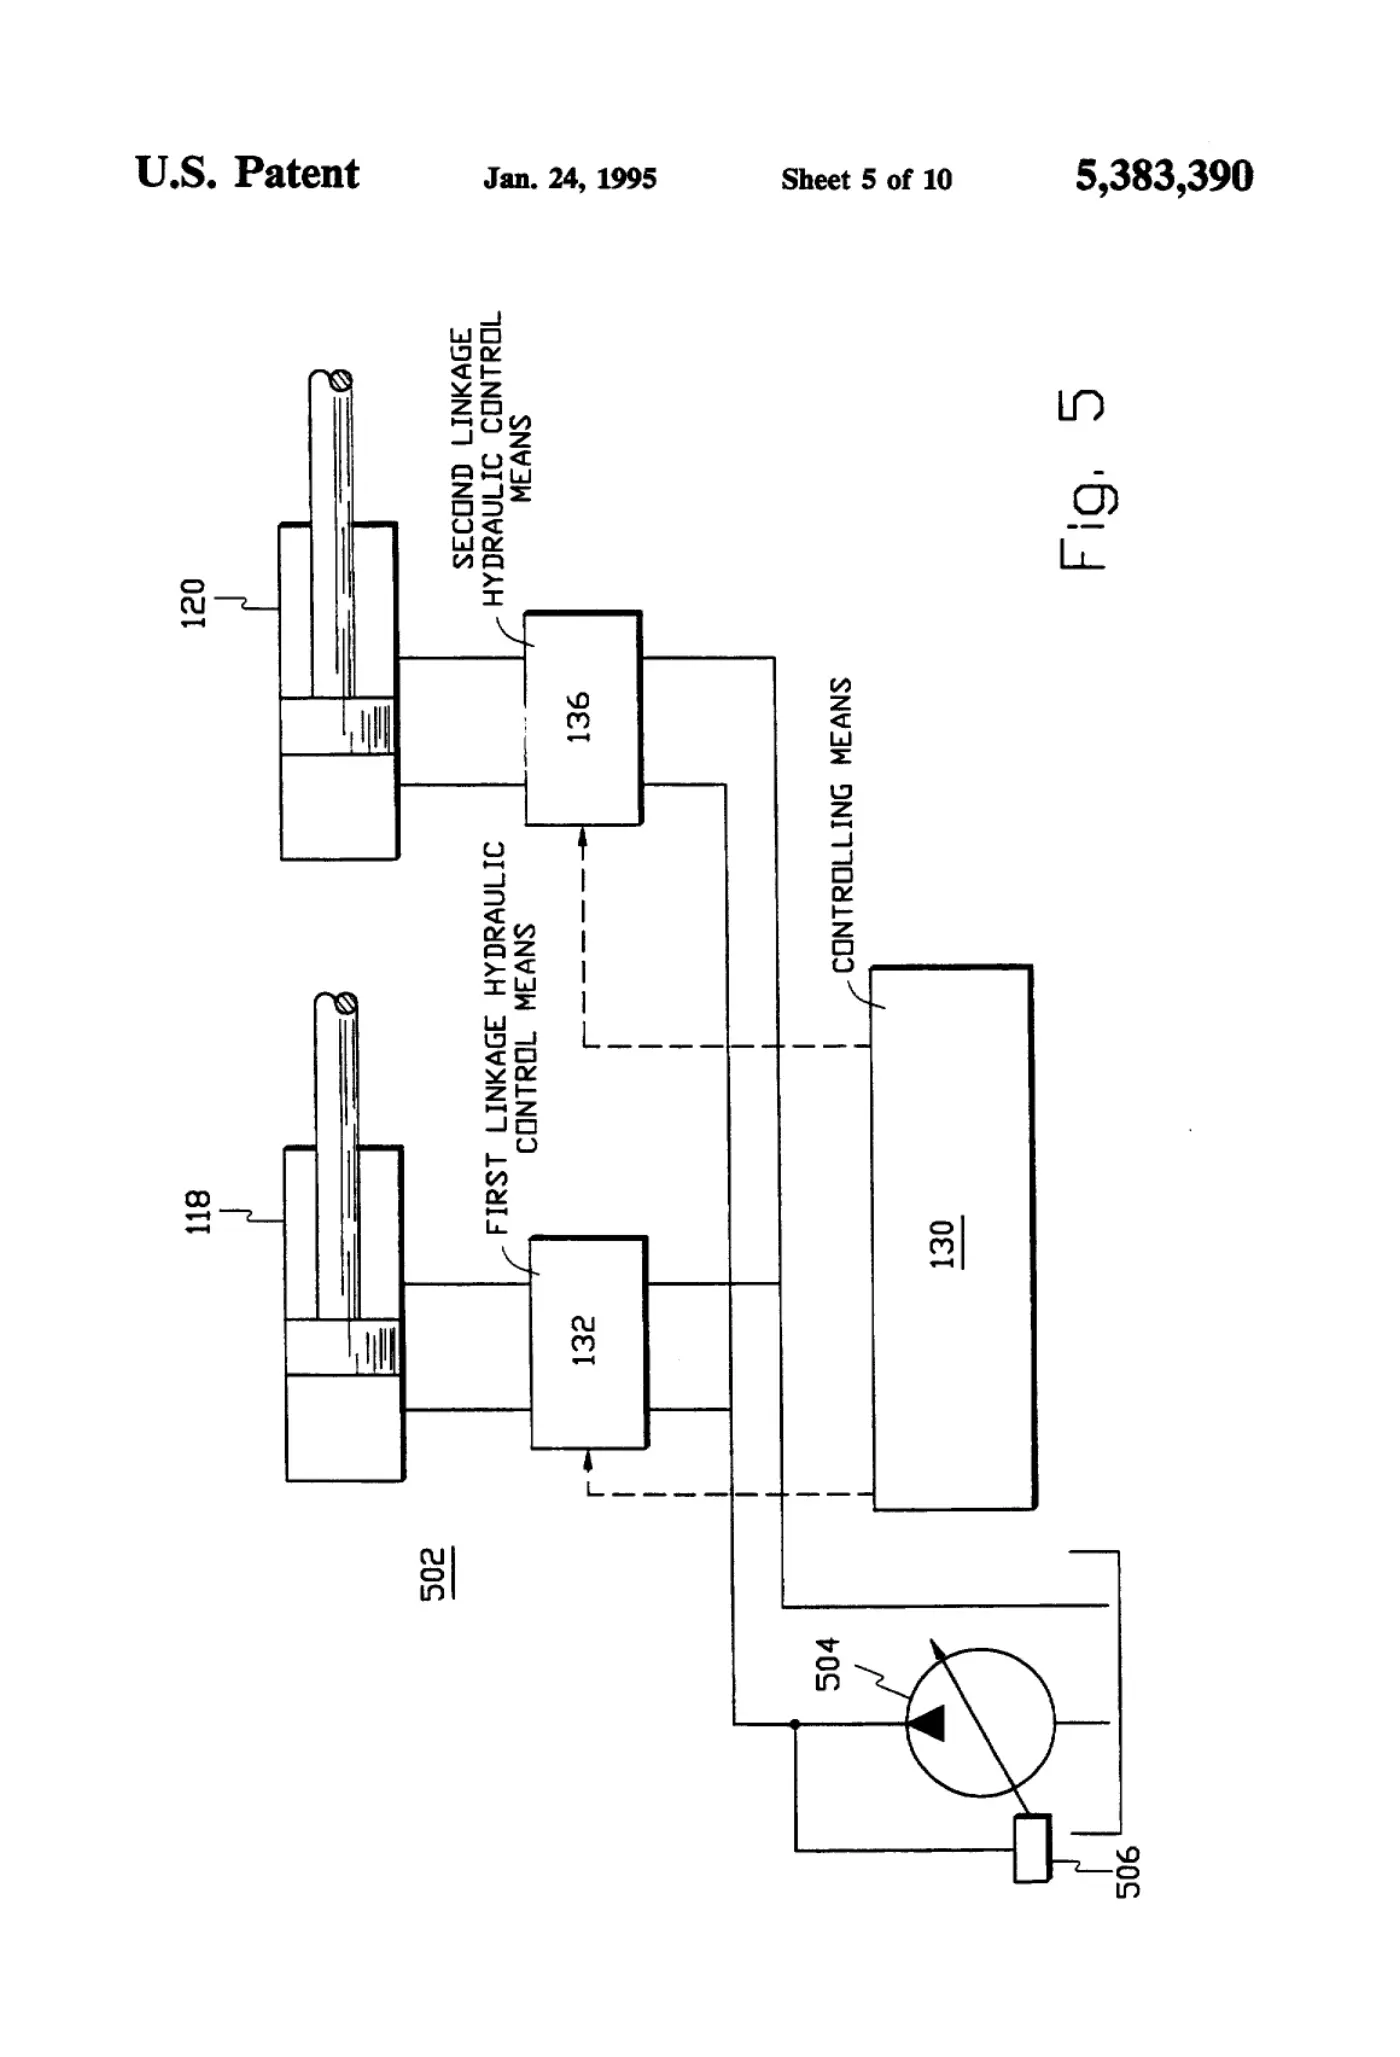
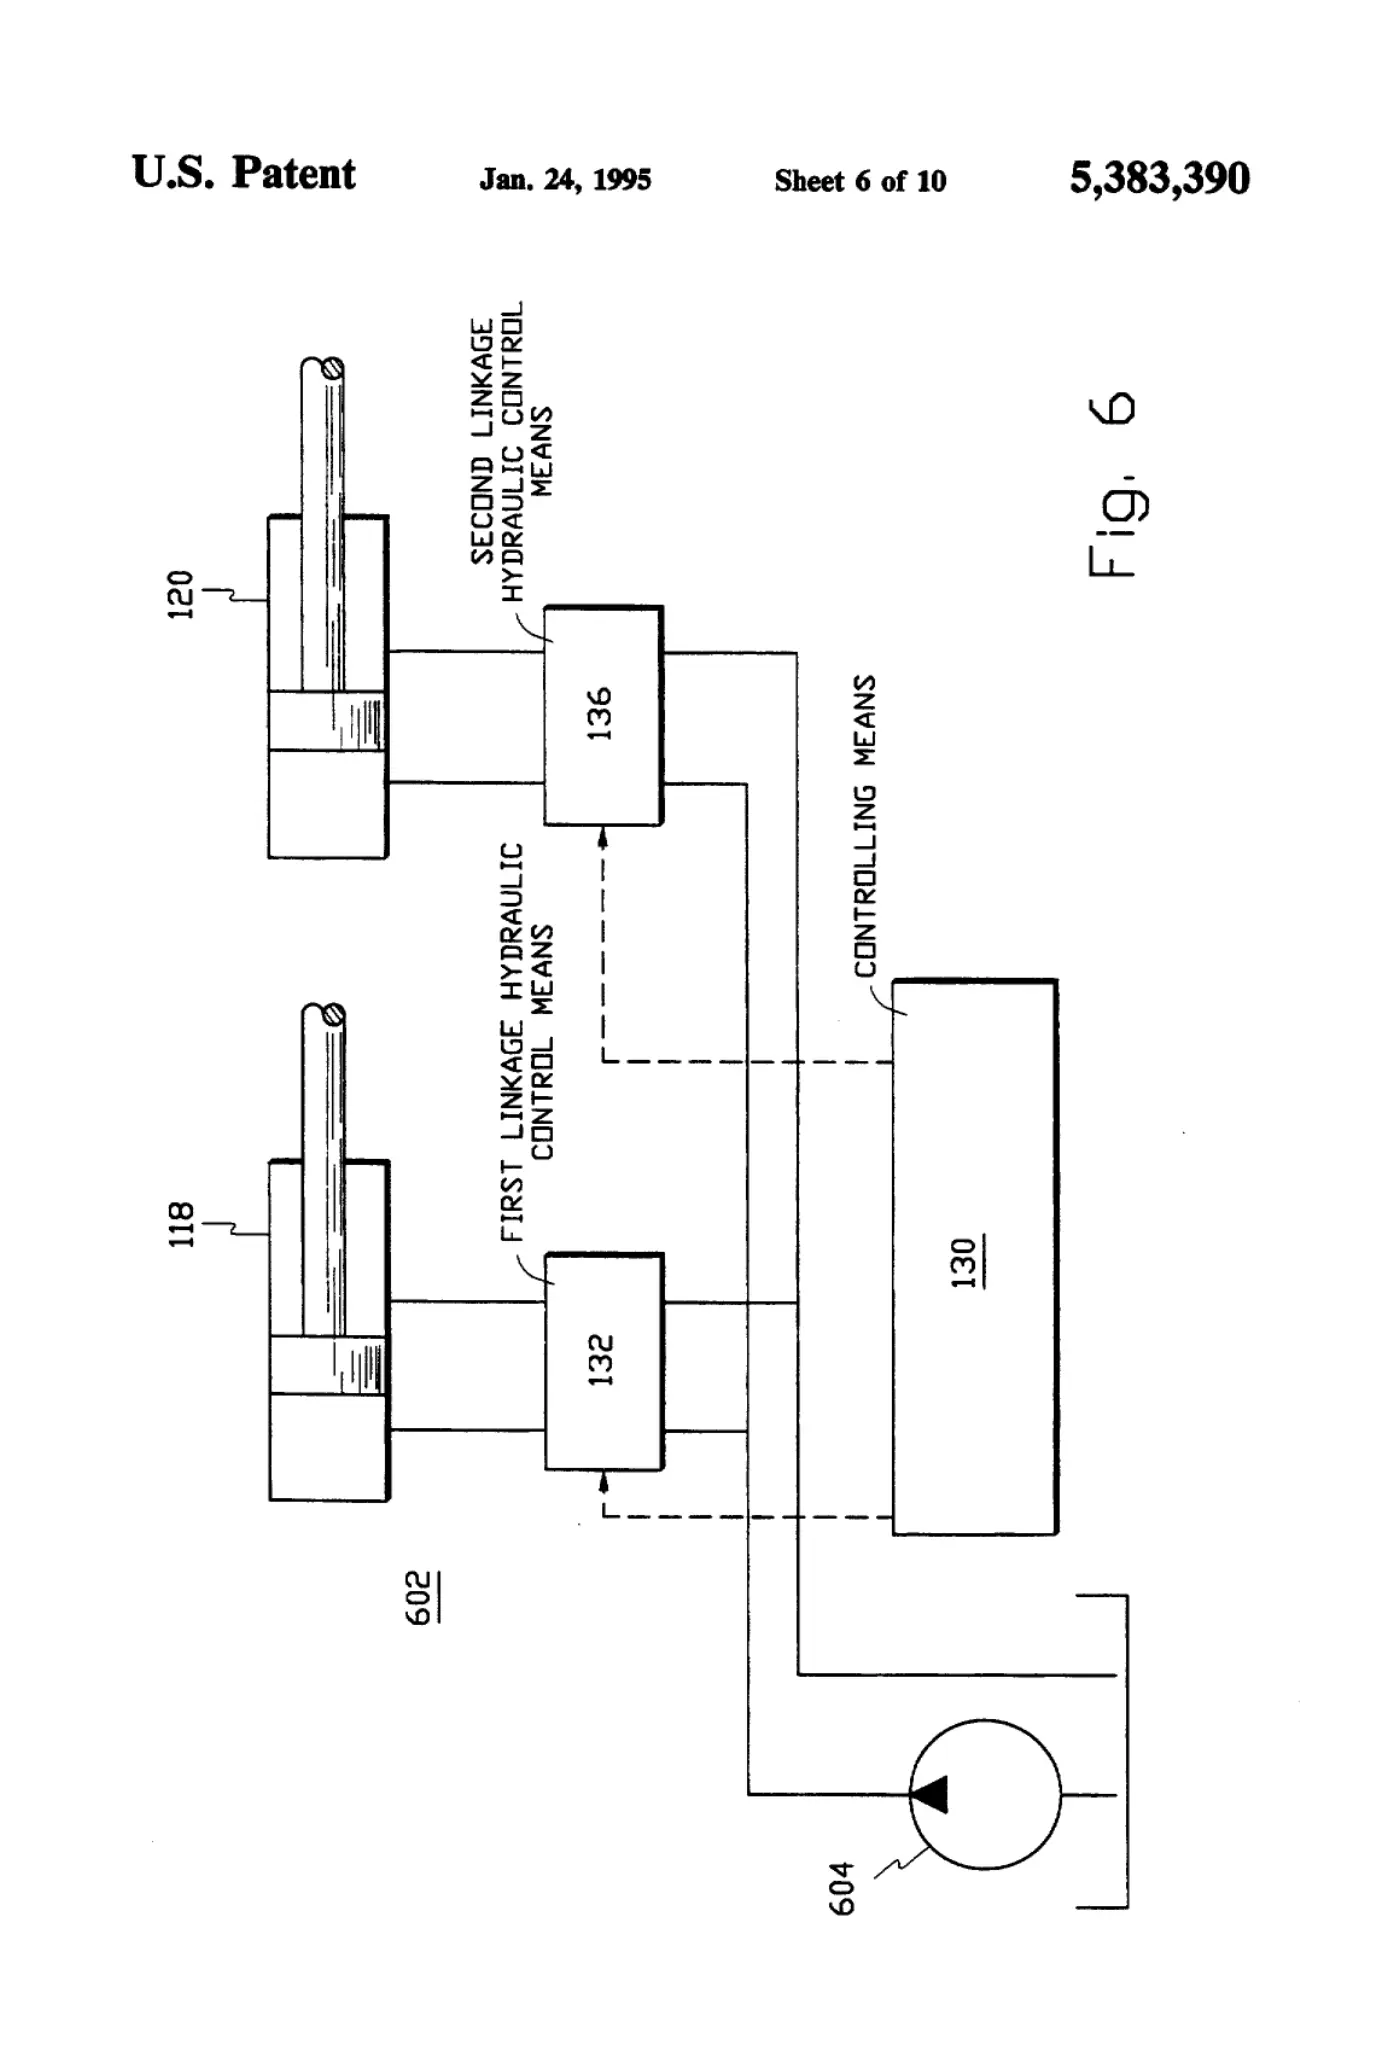
The present invention provides an apparatus for controllably actuating a work implement. The work implement includes at least a first linkage and a second linkage. The apparatus produces a control signal, senses the position and velocity of the first and second linkages and responsively produces position and velocity signals. The apparatus responsively produces a command signal as a function of the control signal and the position and velocity signals. The command signal controls actuation of the first linkage such that dynamic coupling between the first and second linkages is minimized.
Abstract
The present invention provides an apparatus for controllably actuating a work implement. The work implement includes at least a first linkage and a second linkage. The apparatus produces a control signal, senses the position and velocity of the first and second linkages and responsively produces position and velocity signals. The apparatus responsively produces a command signal as a function of the control signal and the position and velocity signals. The command signal controls actuation of the first linkage such that dynamic coupling between the first and second linkages is minimized.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
[0005]Sheet 5.
[0006]Sheet 6.
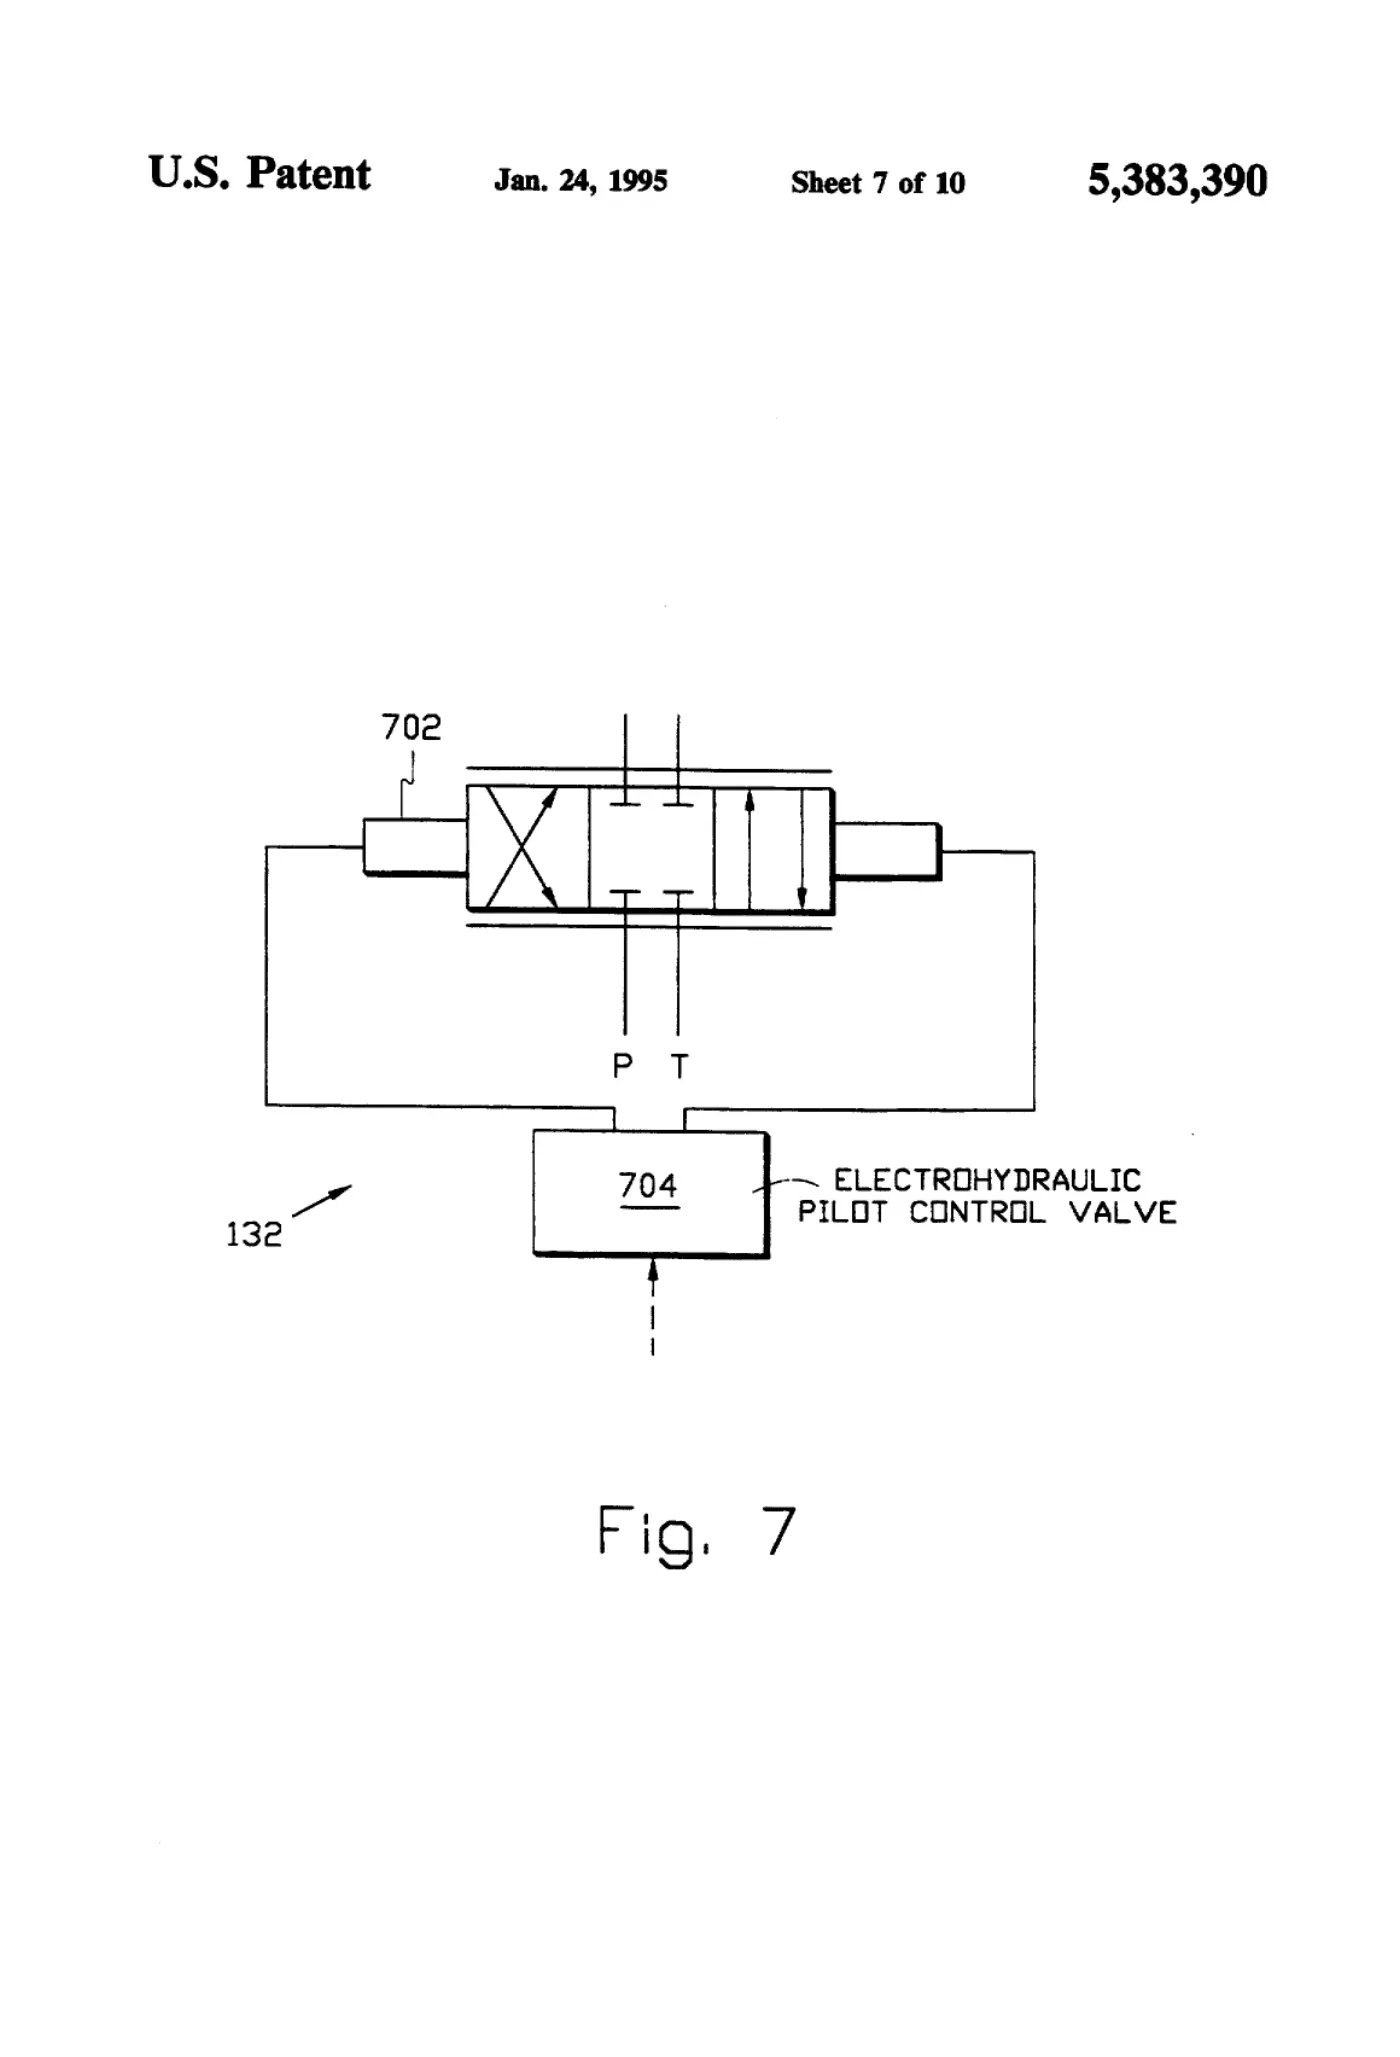
[0007]Sheet 7.
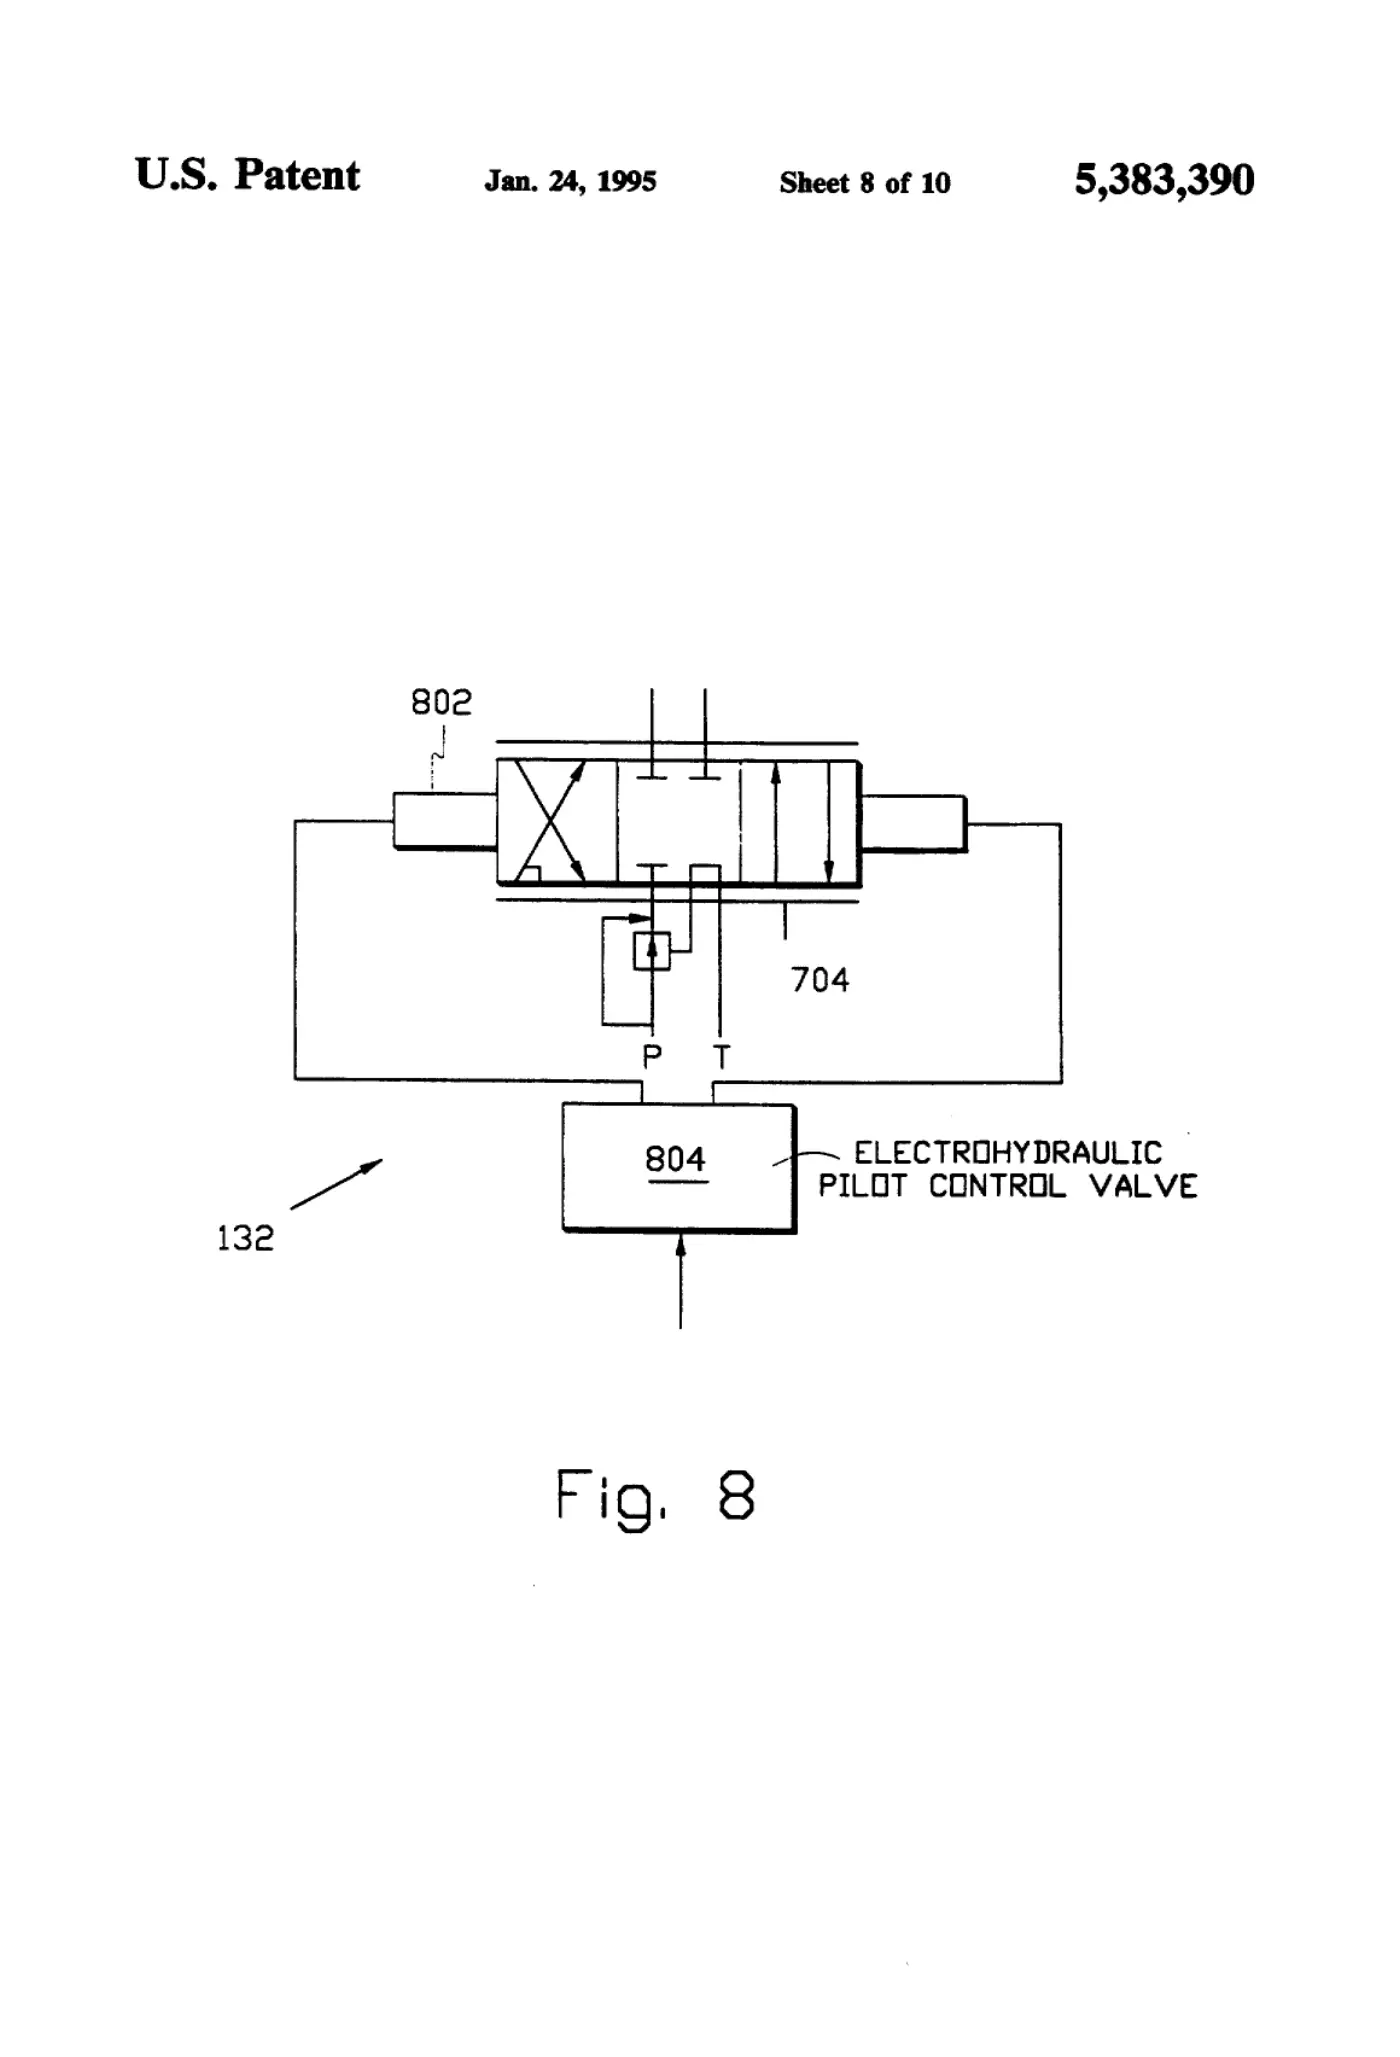
[0008]Sheet 8.
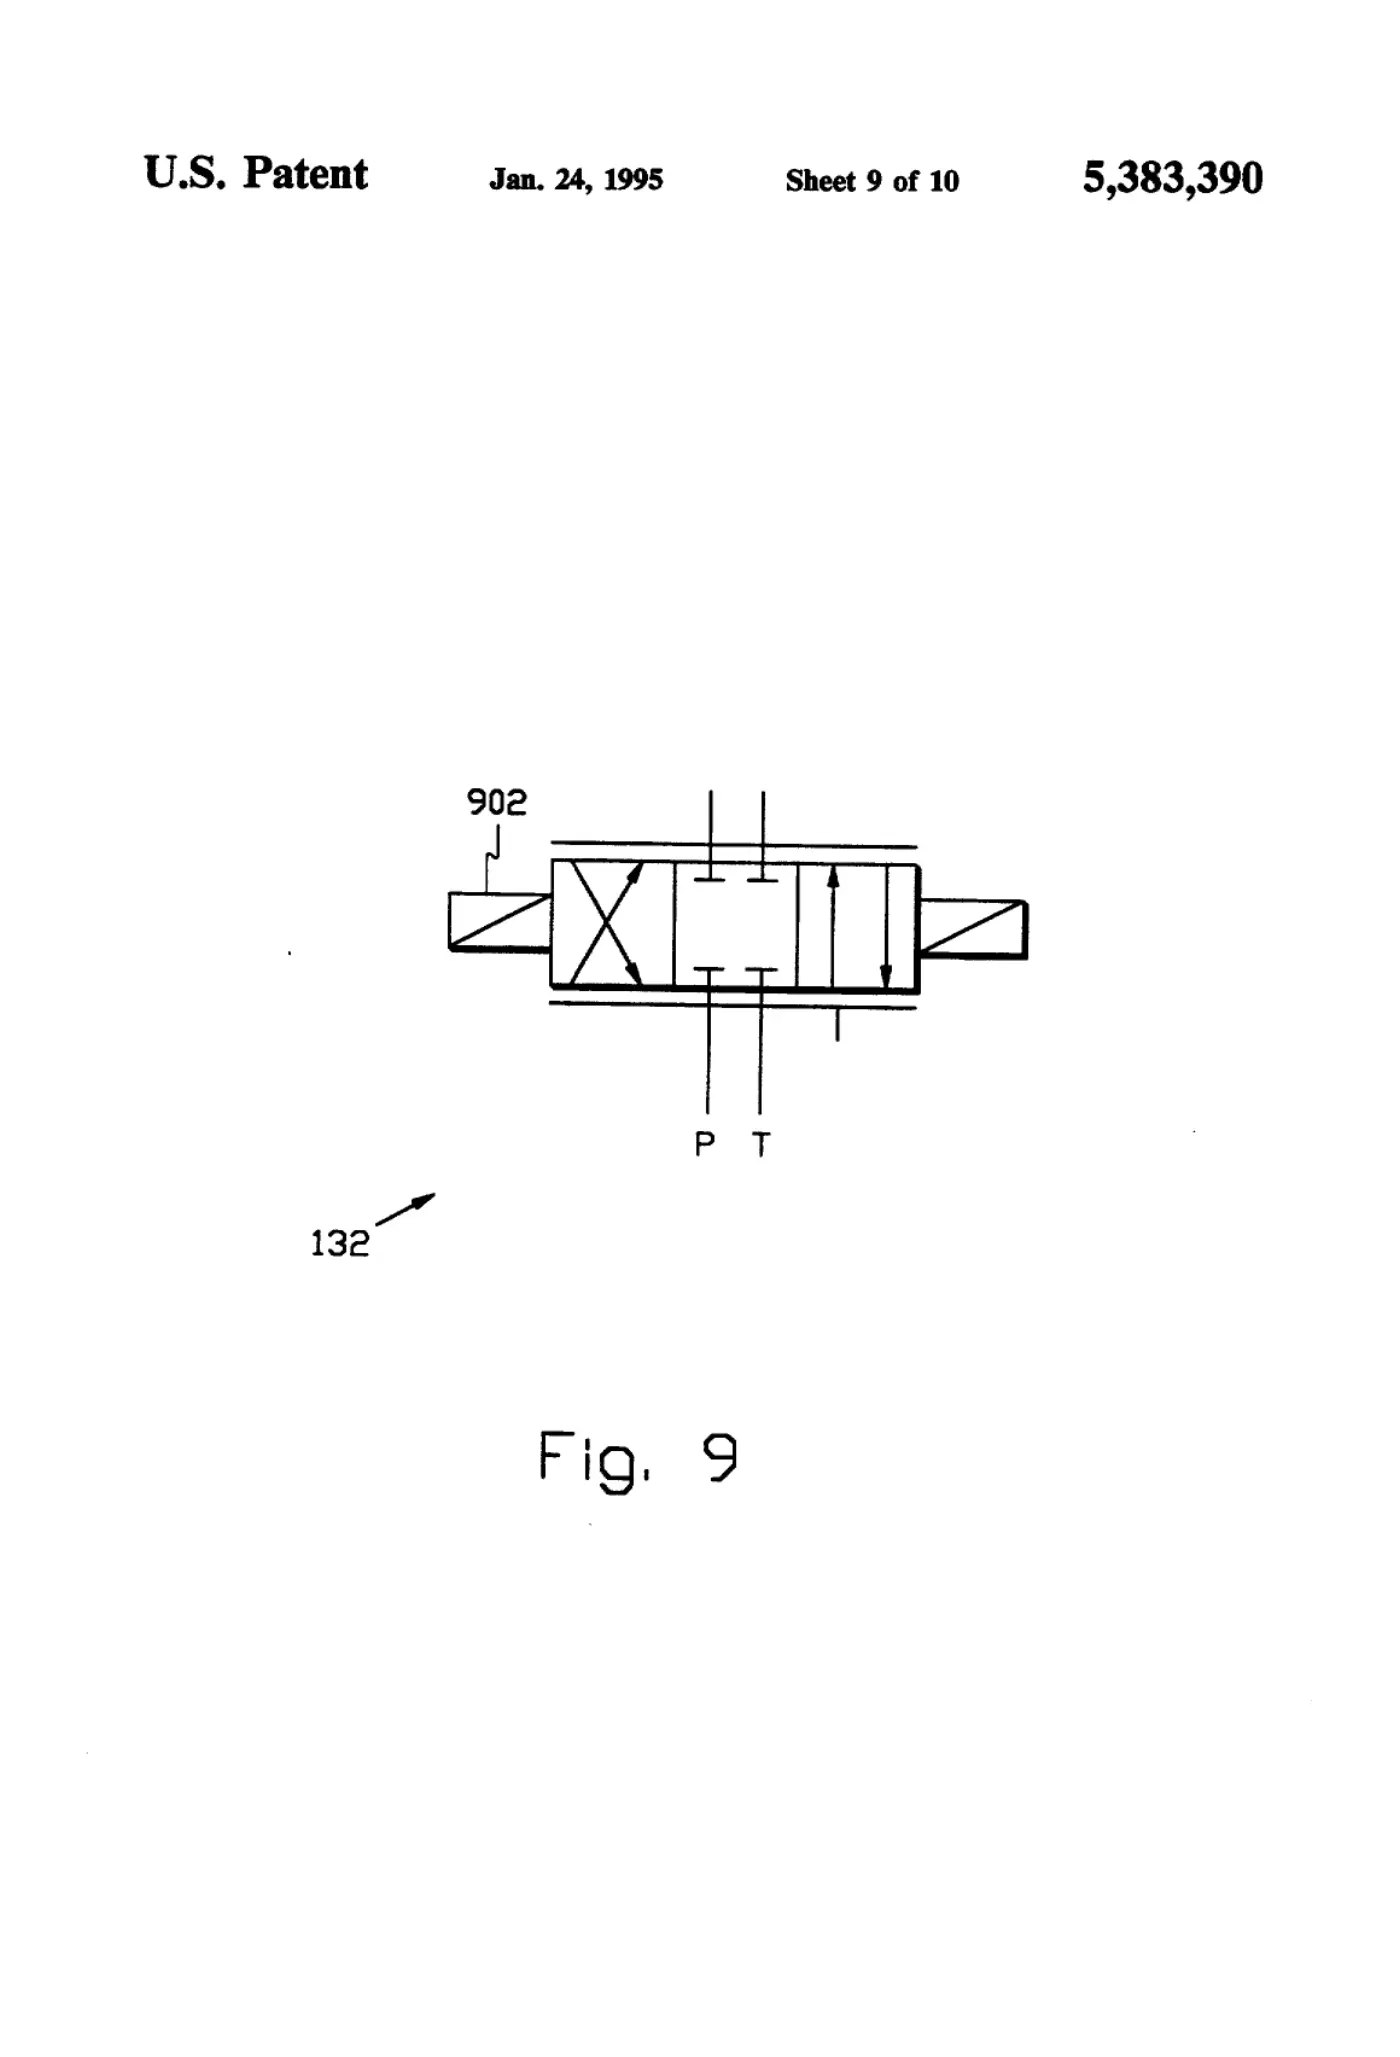
[0009]Sheet 9.
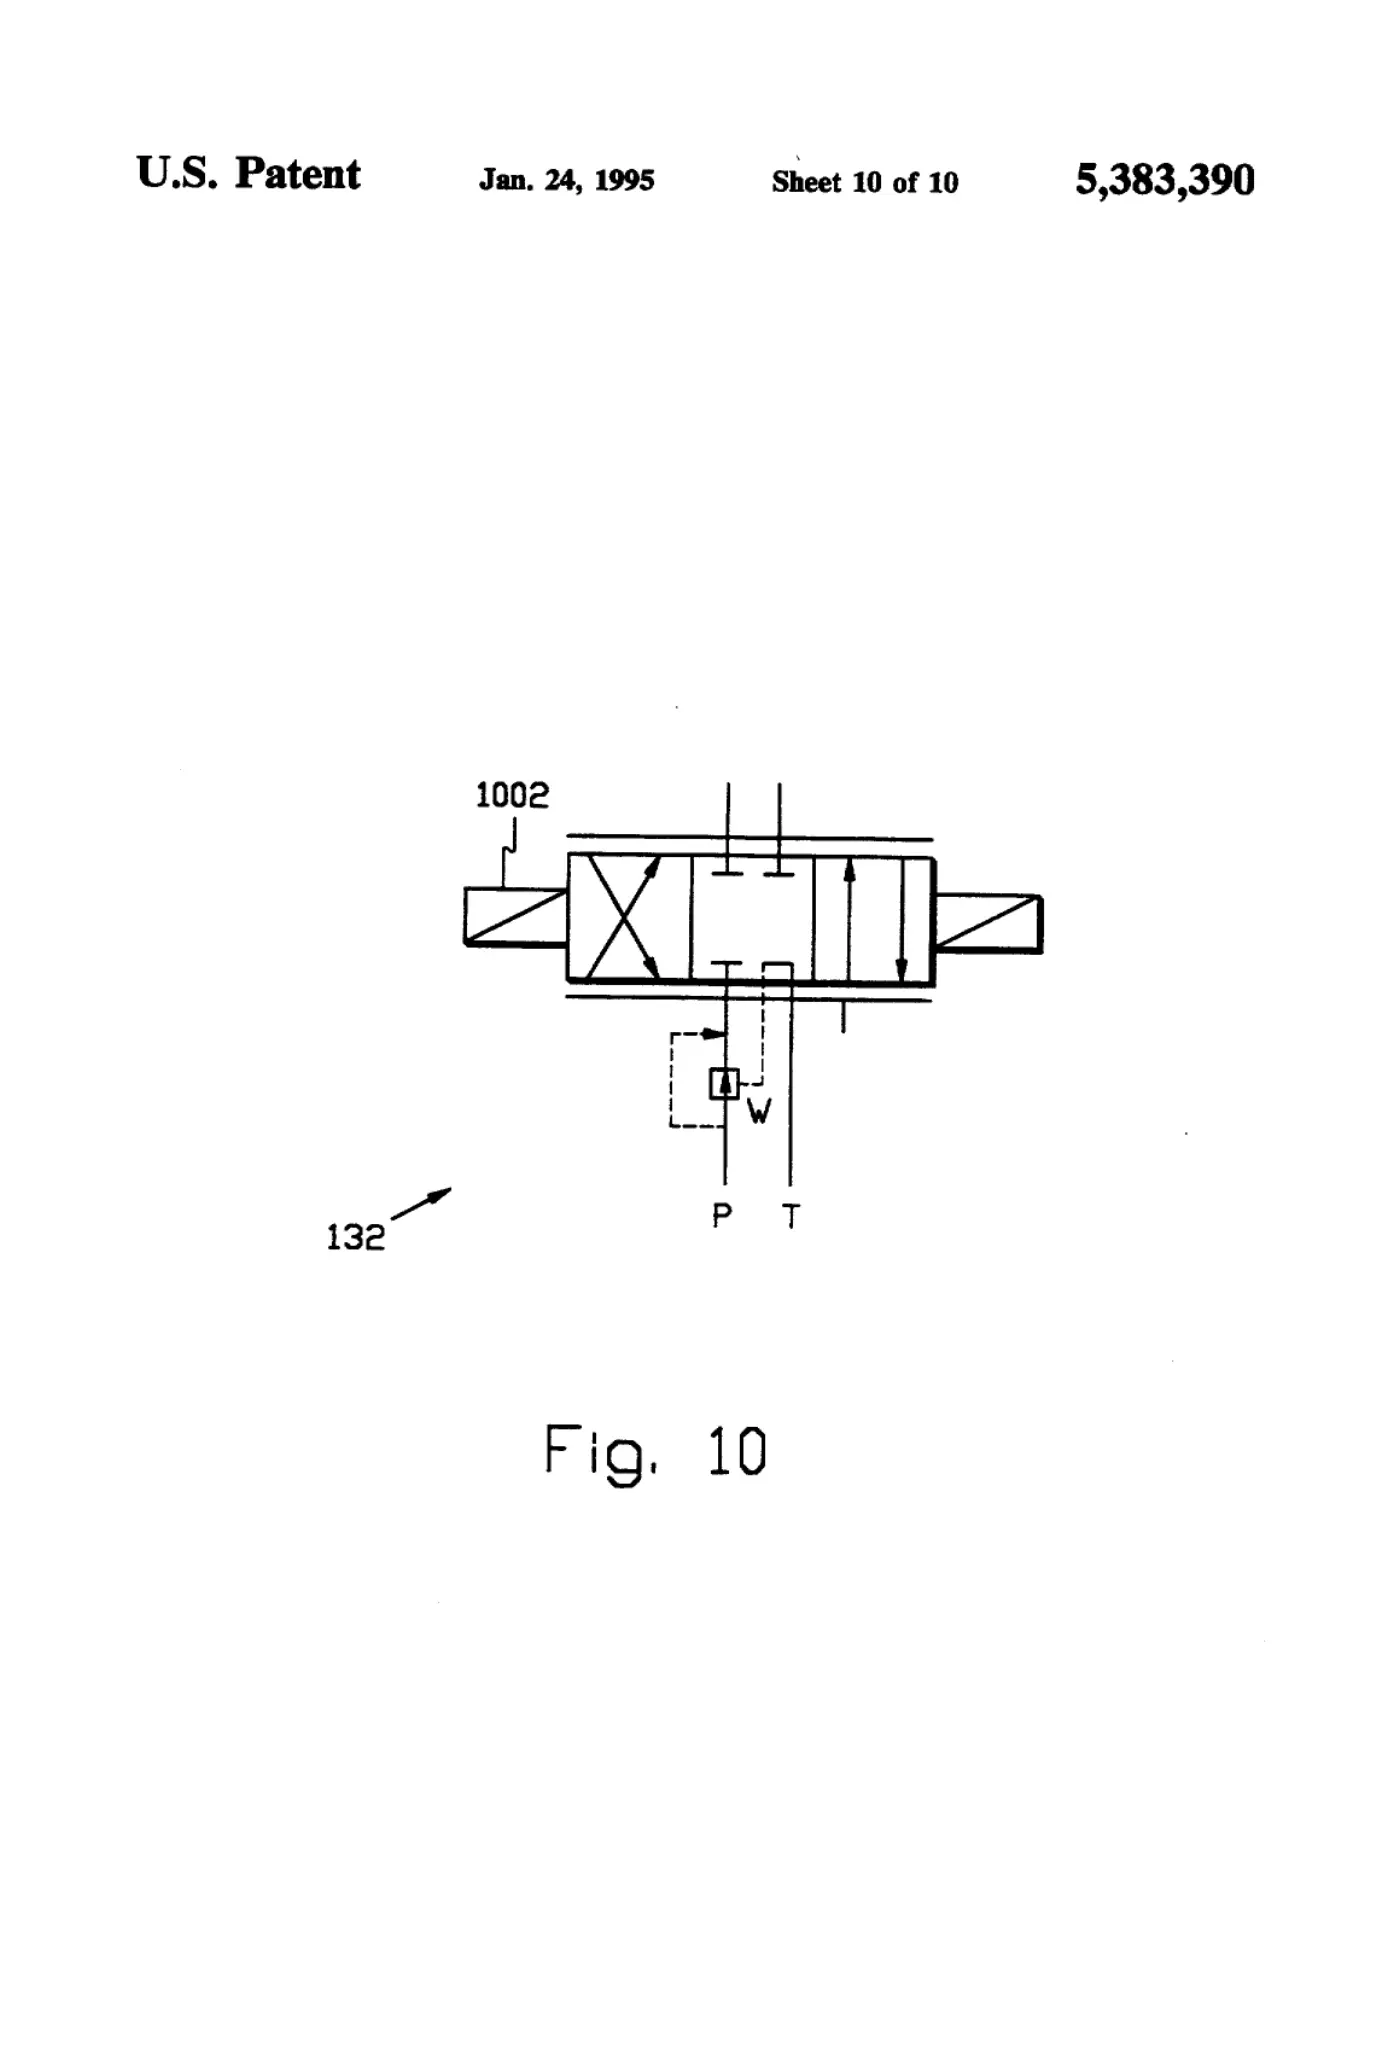
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003321, “Multi-variable control of multi-degree of freedom linkages,” published September 15, 2026 at 20:09:23 UTC, https://opentechnical.org/p/OT-2026-000003321.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.