OT-2026-000003346
Direct drive robotic system
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003346
- Classification
- Robotics & Automation › Robot Architectures
- Assignee
- ADEPT TECHNOLOGY INC
- Original source
- US-5314293-A, the United States Patent and Trademark Office, 24 May 1994
- Document SHA-256
- 14e3d43051a921fd1bf3a697bbb36630a4b8e1e64d4843be3e211ae734c68000
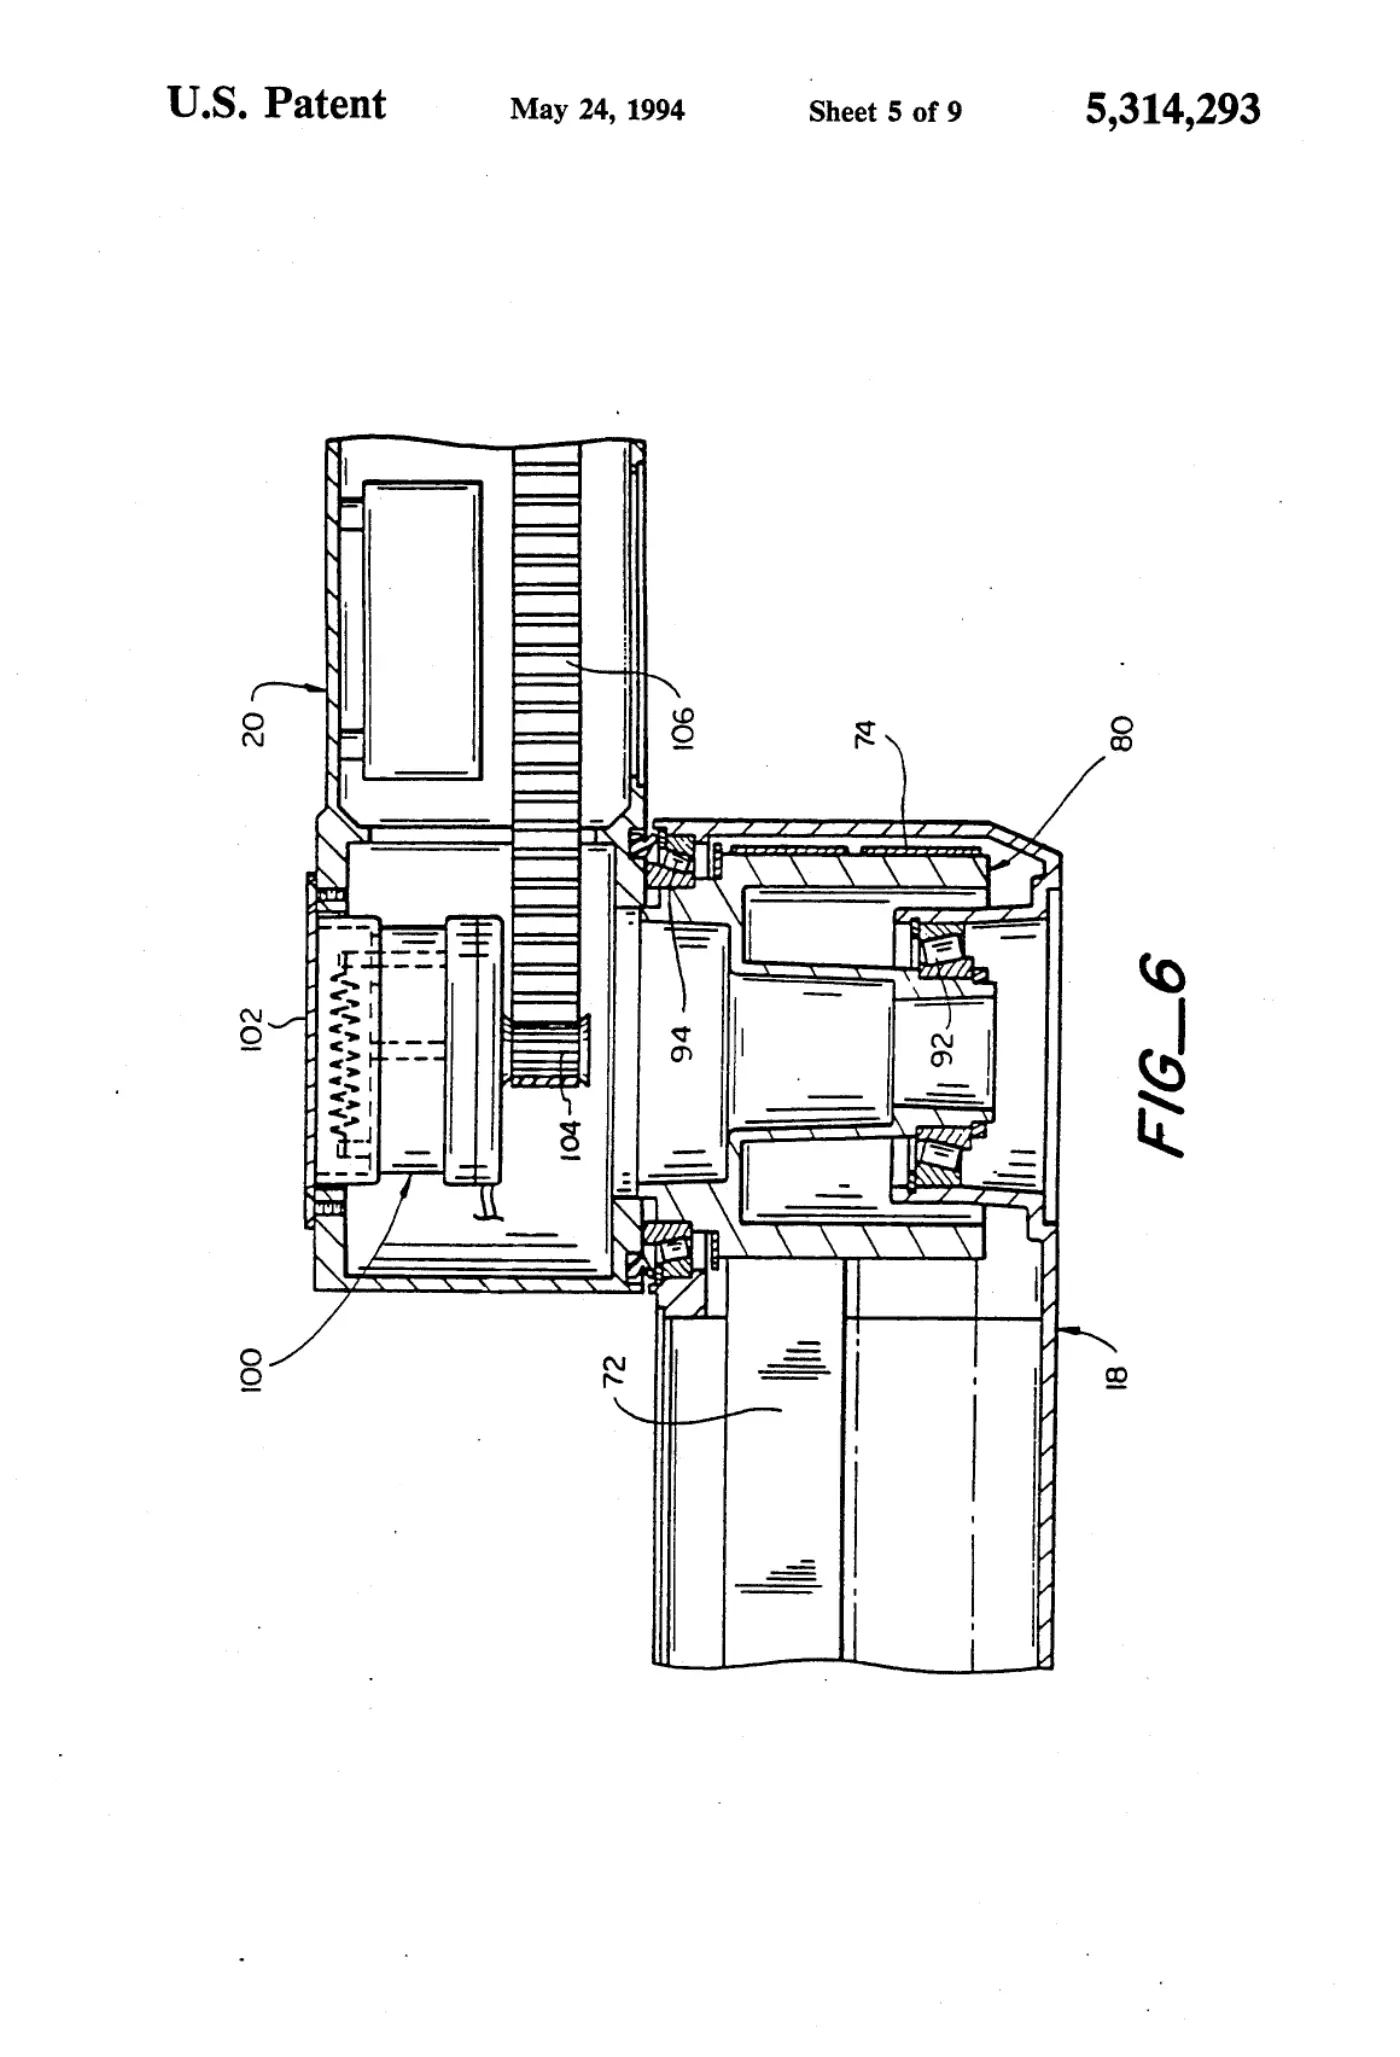
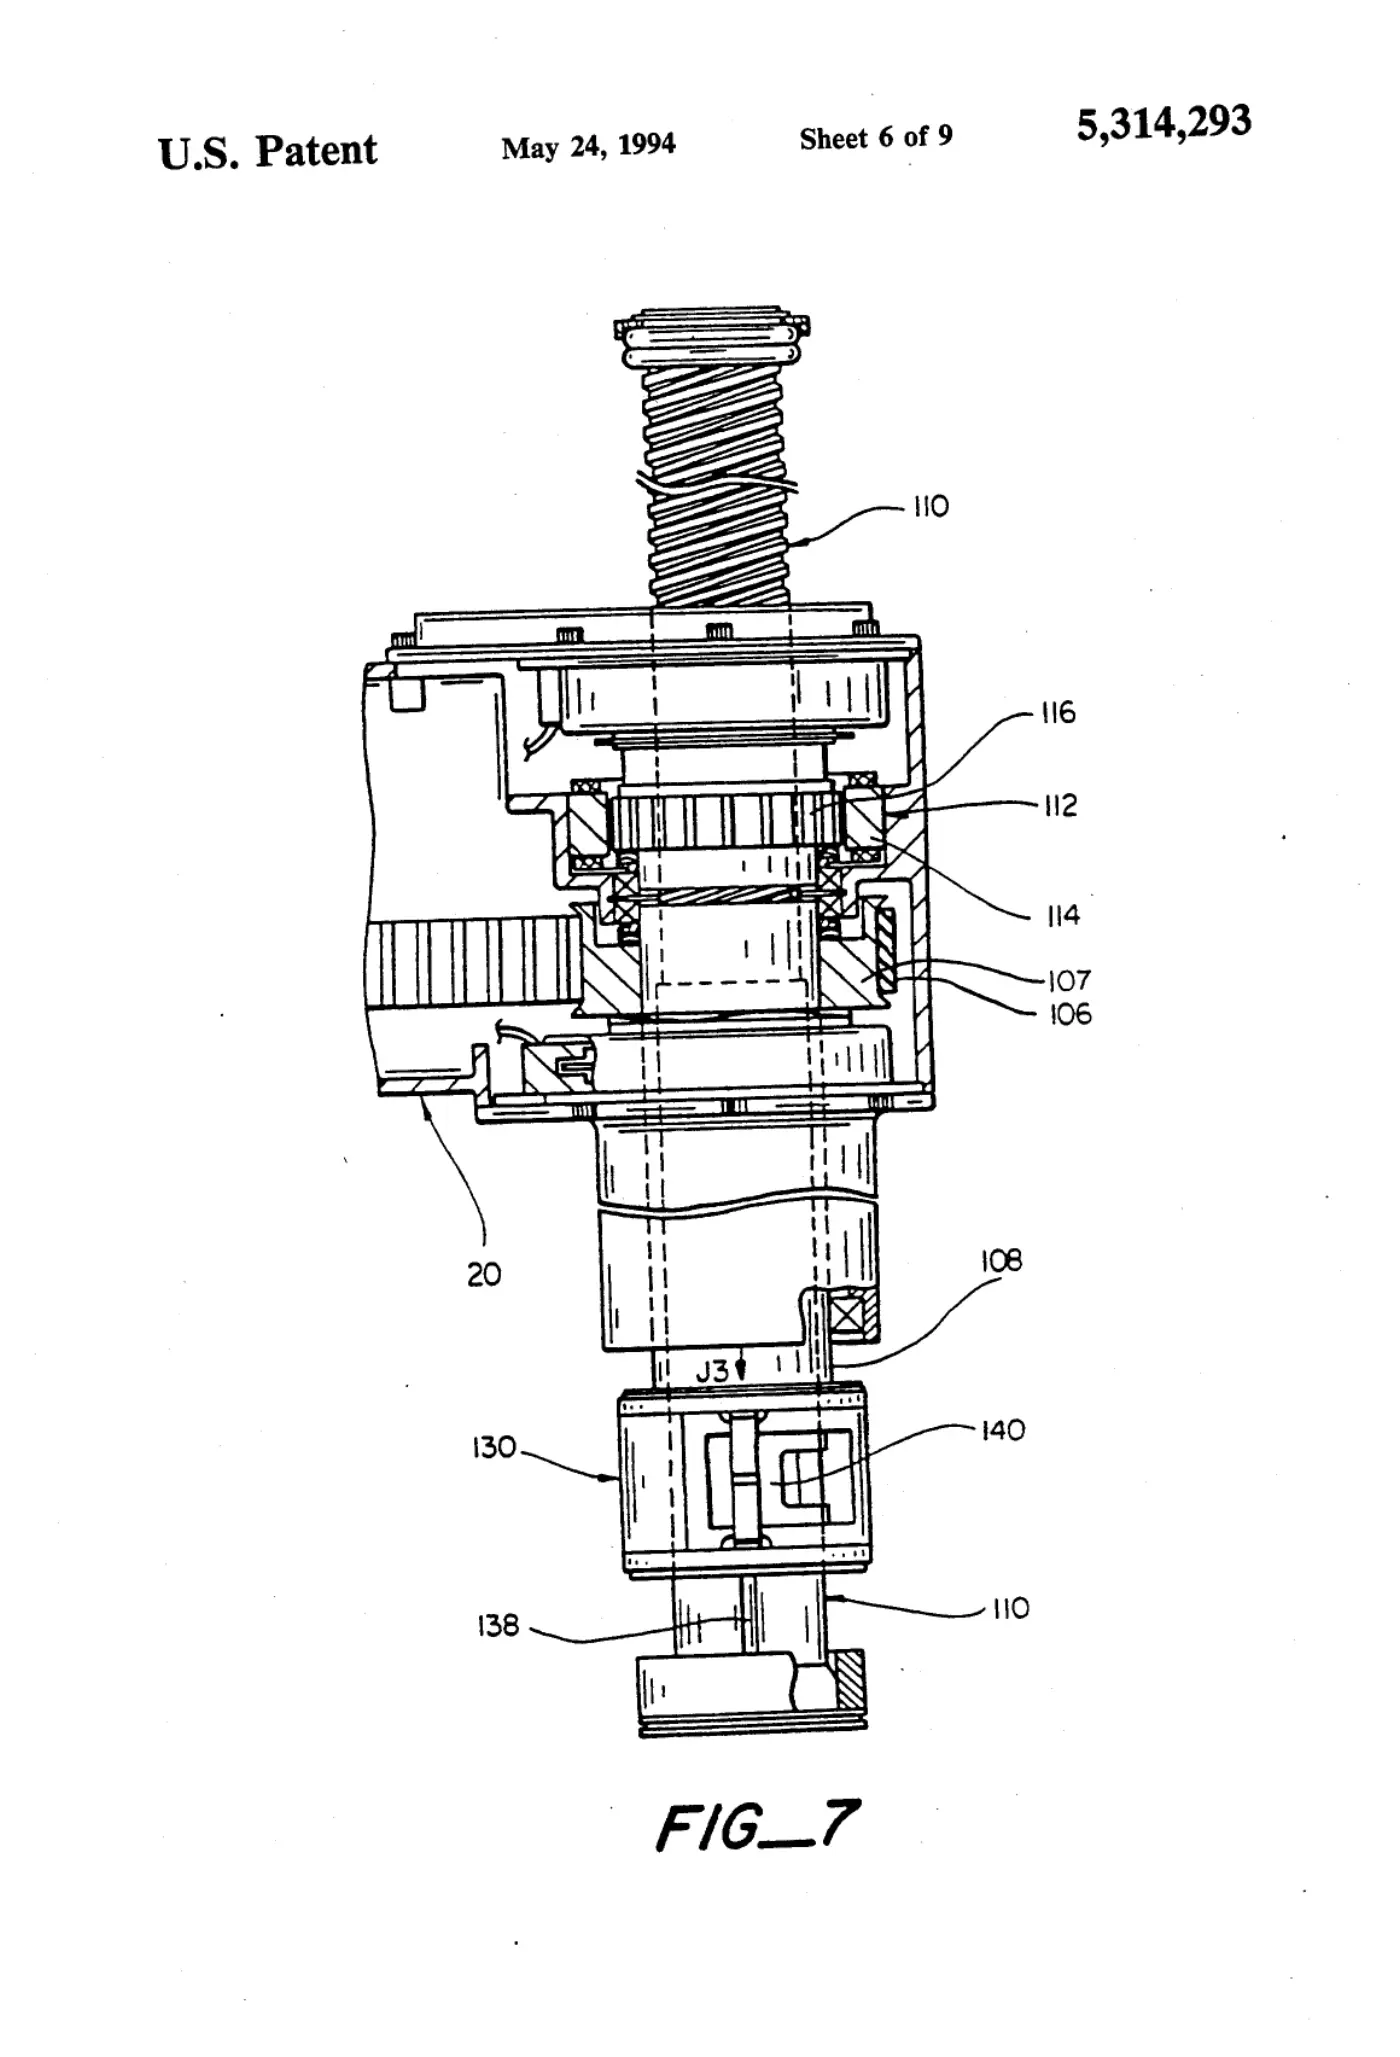
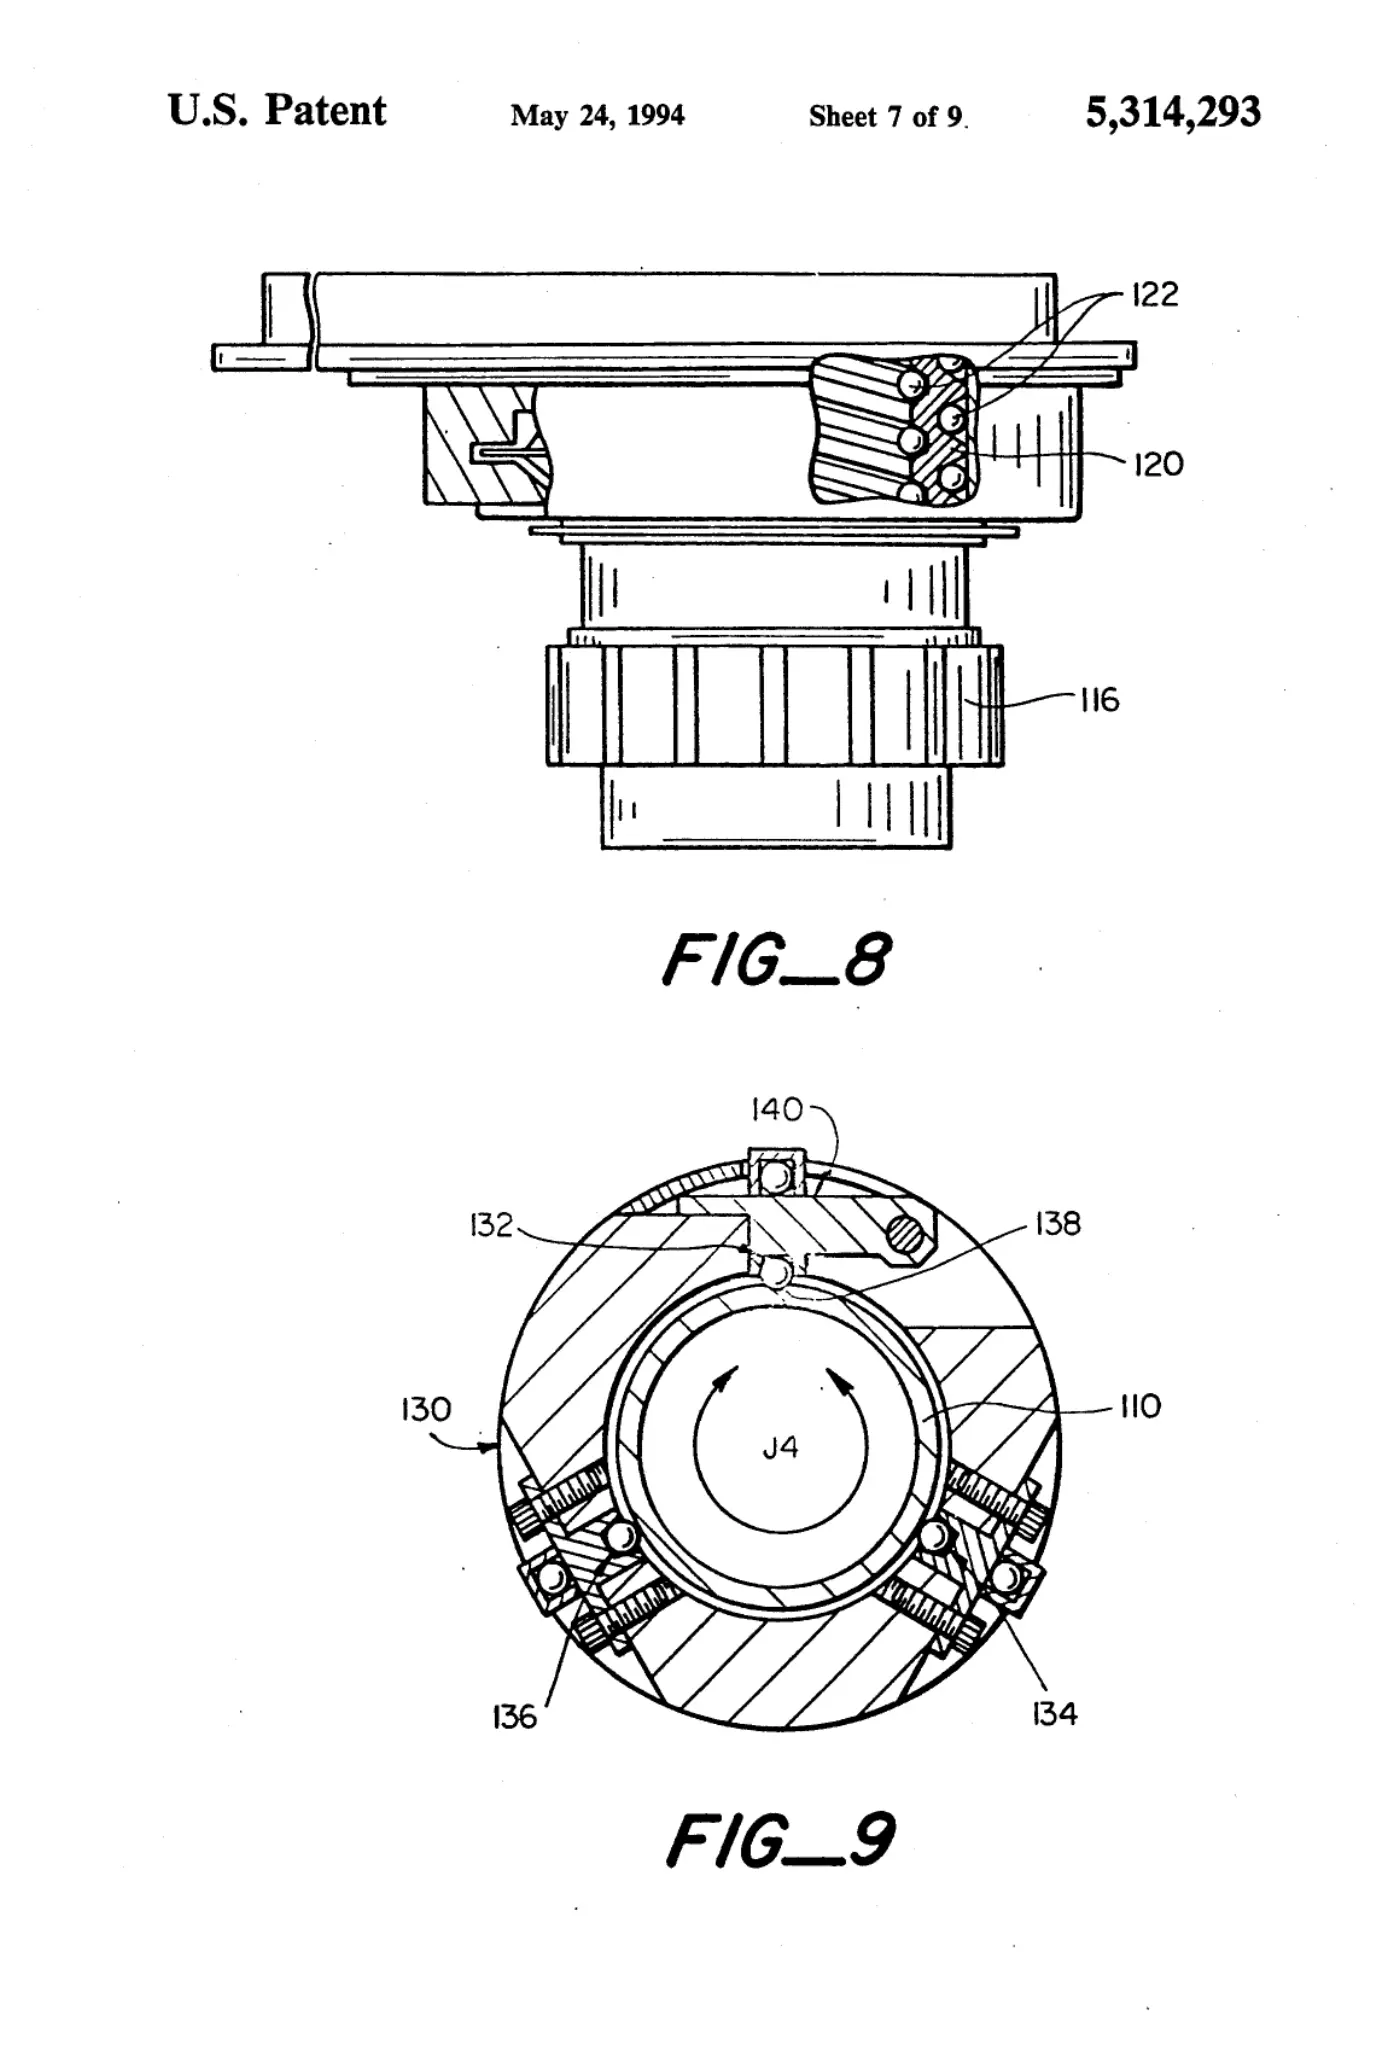
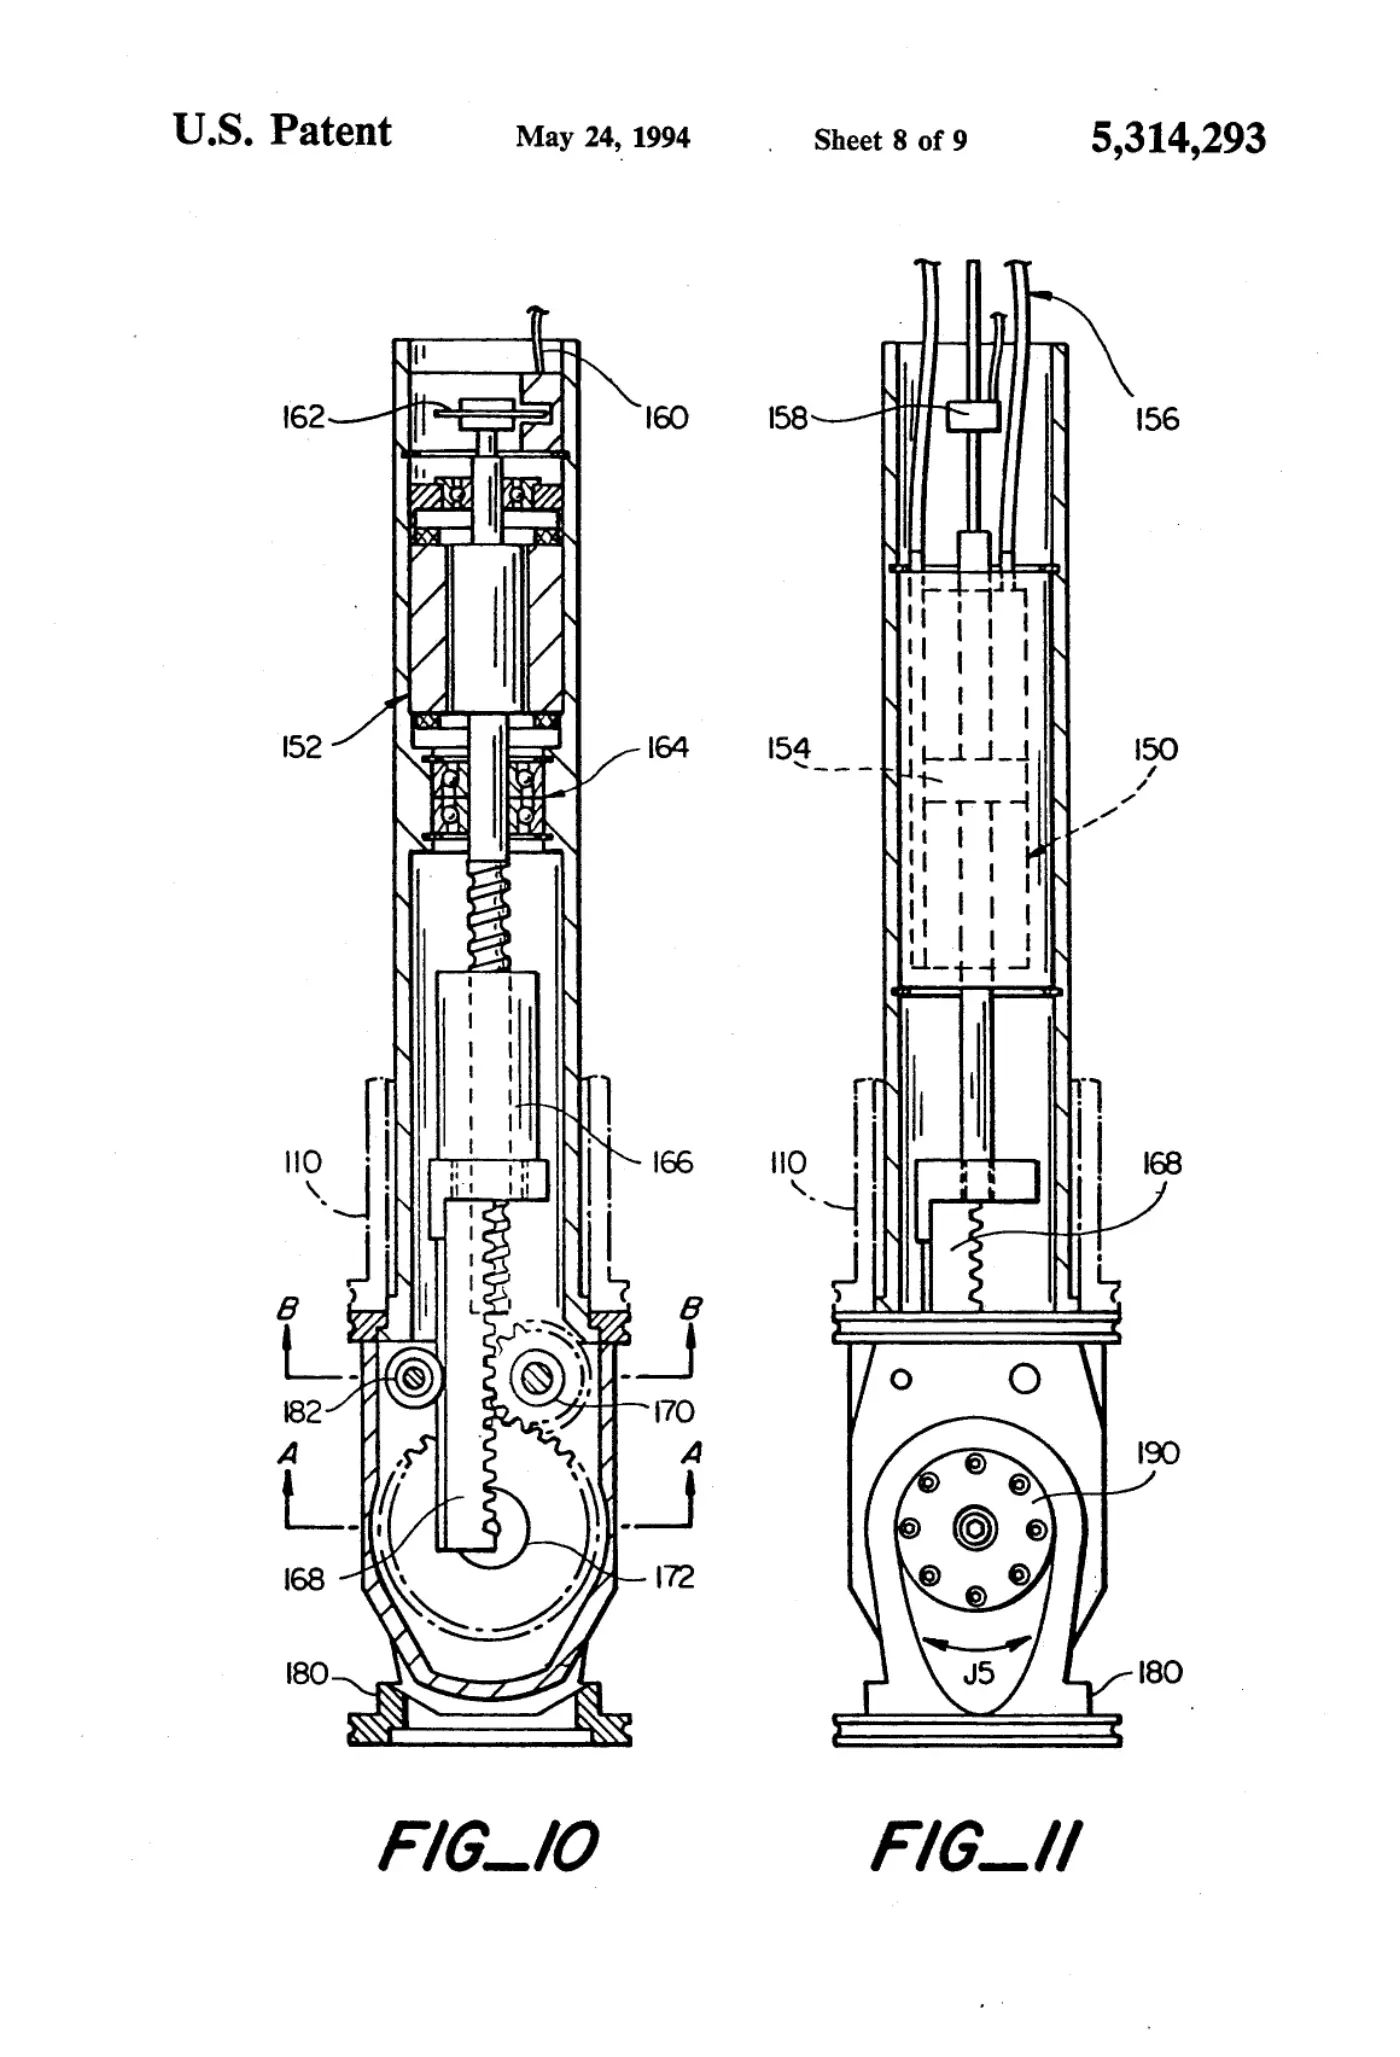
An articulated direct drive robotic manipulator providing rotation of first and second arms about first and second parallel axes including first and second motors for driving the rotation of the first and second arms. A pedestal is mounted on a base, the first motor is directly coupled to a rotatable column in the pedestal for providing a first robot arm with a first degree of freedom, a second motor is coupled to a rotatable column coaxial to the first column for providing the manipulator with a second degree of freedom by rotation of the second arm. The distal end of the second arm includes support for an end effector for movement about a third axis which is a vertical axis and a fourth axis which is a rotational axis and support for a quill. Also included is a modular device adapted to be coupled to the end of the quill which can move within horizontal planes passing through the third axis to provide a fifth degree of freedom.
Abstract
An articulated direct drive robotic manipulator providing rotation of first and second arms about first and second parallel axes including first and second motors for driving the rotation of the first and second arms. A pedestal is mounted on a base, the first motor is directly coupled to a rotatable column in the pedestal for providing a first robot arm with a first degree of freedom, a second motor is coupled to a rotatable column coaxial to the first column for providing the manipulator with a second degree of freedom by rotation of the second arm. The distal end of the second arm includes support for an end effector for movement about a third axis which is a vertical axis and a fourth axis which is a rotational axis and support for a quill. Also included is a modular device adapted to be coupled to the end of the quill which can move within horizontal planes passing through the third axis to provide a fifth degree of freedom.
1. Drawings
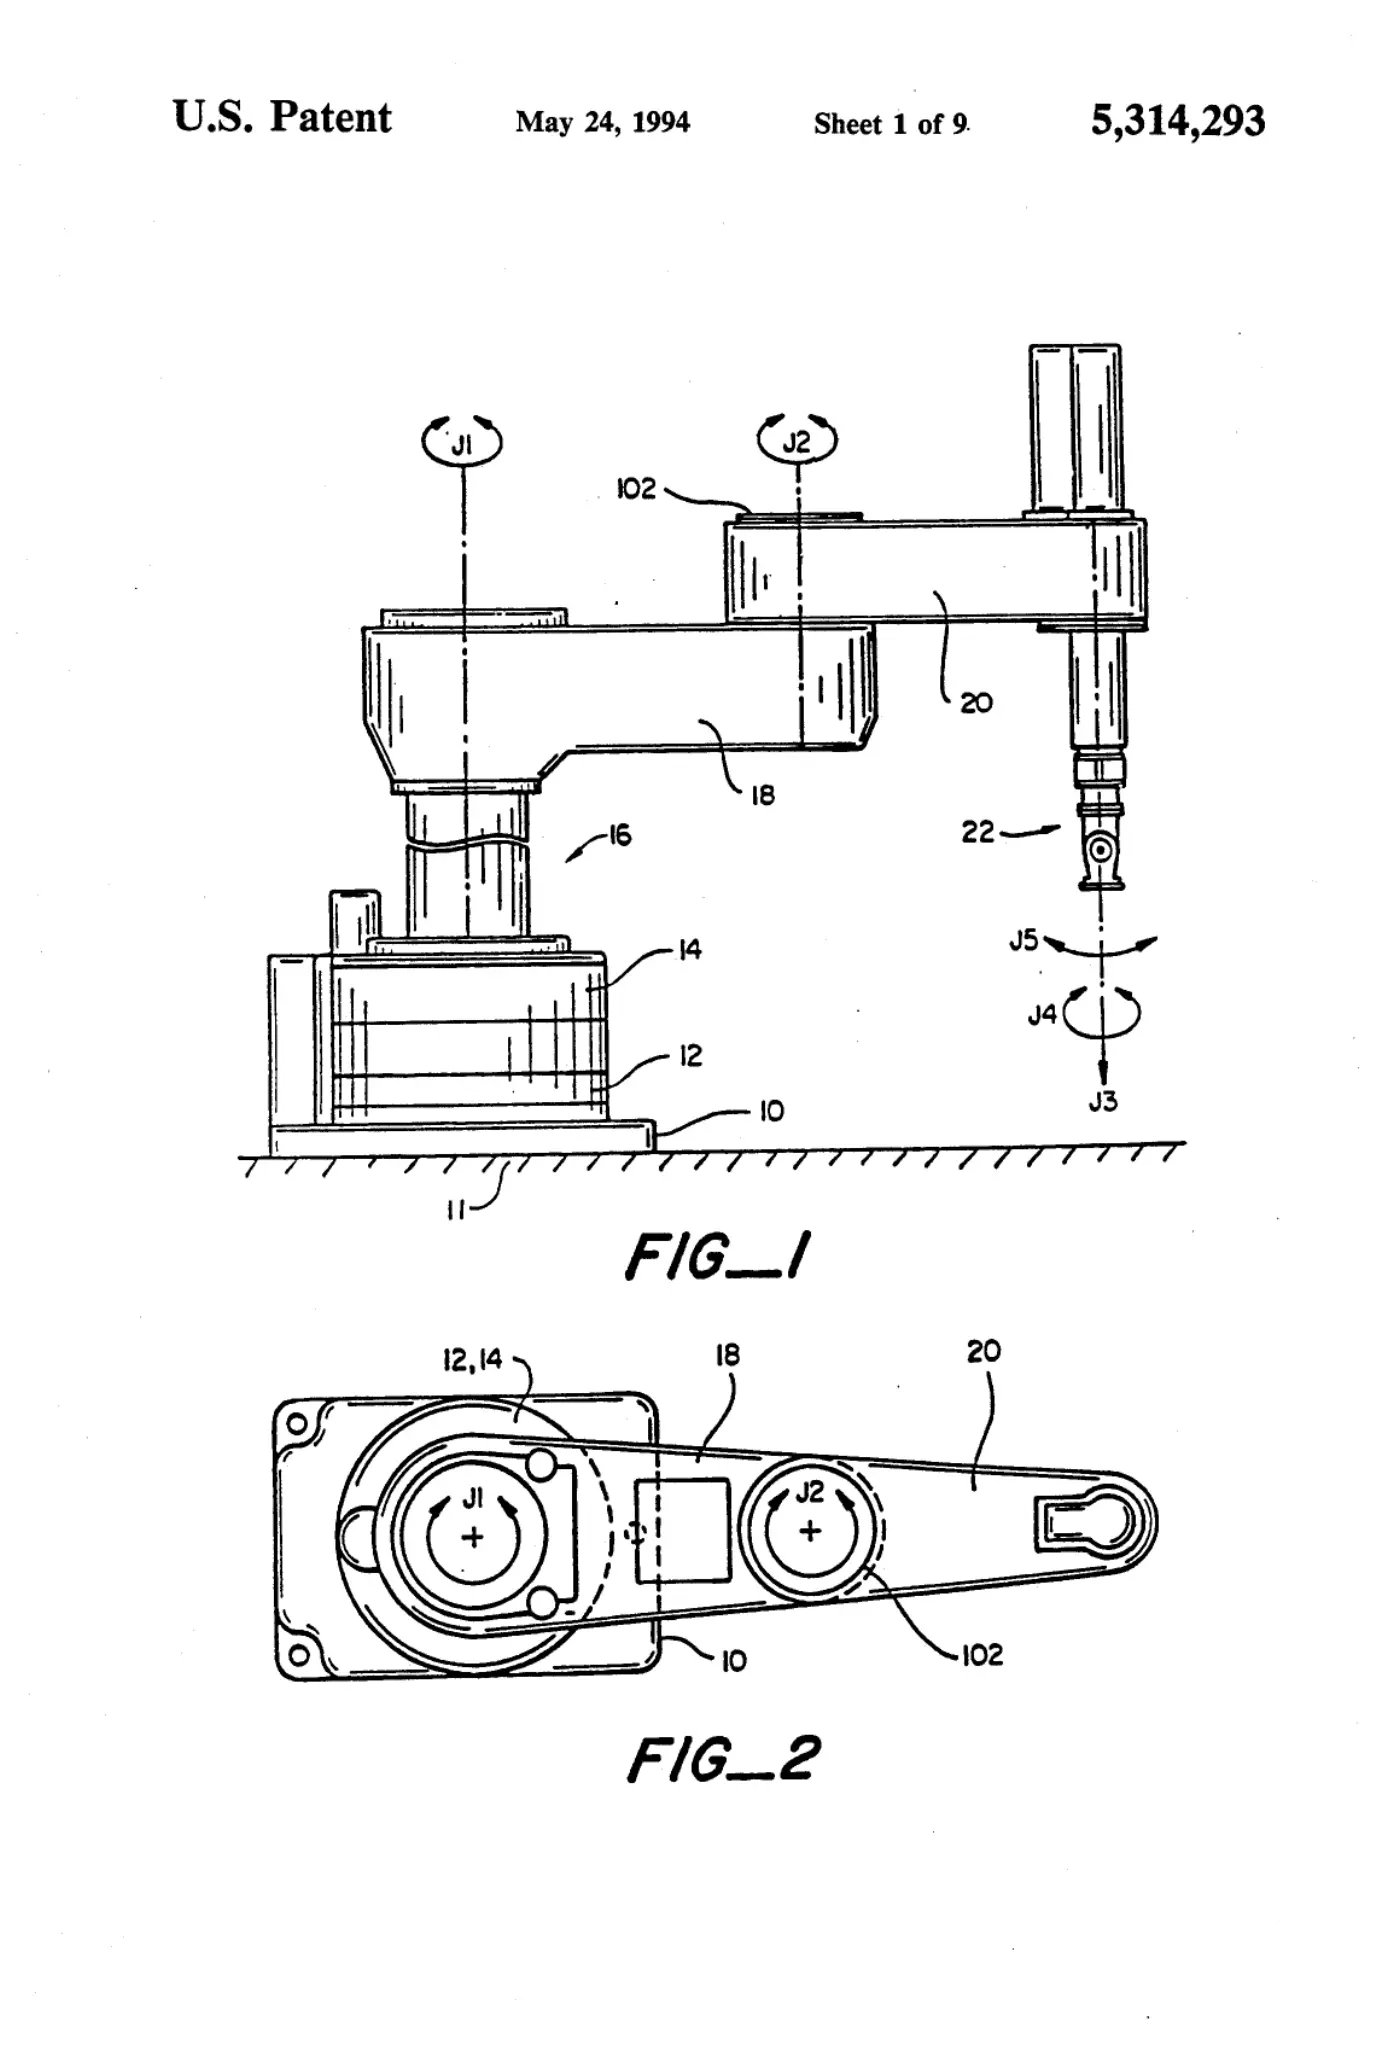
[0001]Sheet 1.
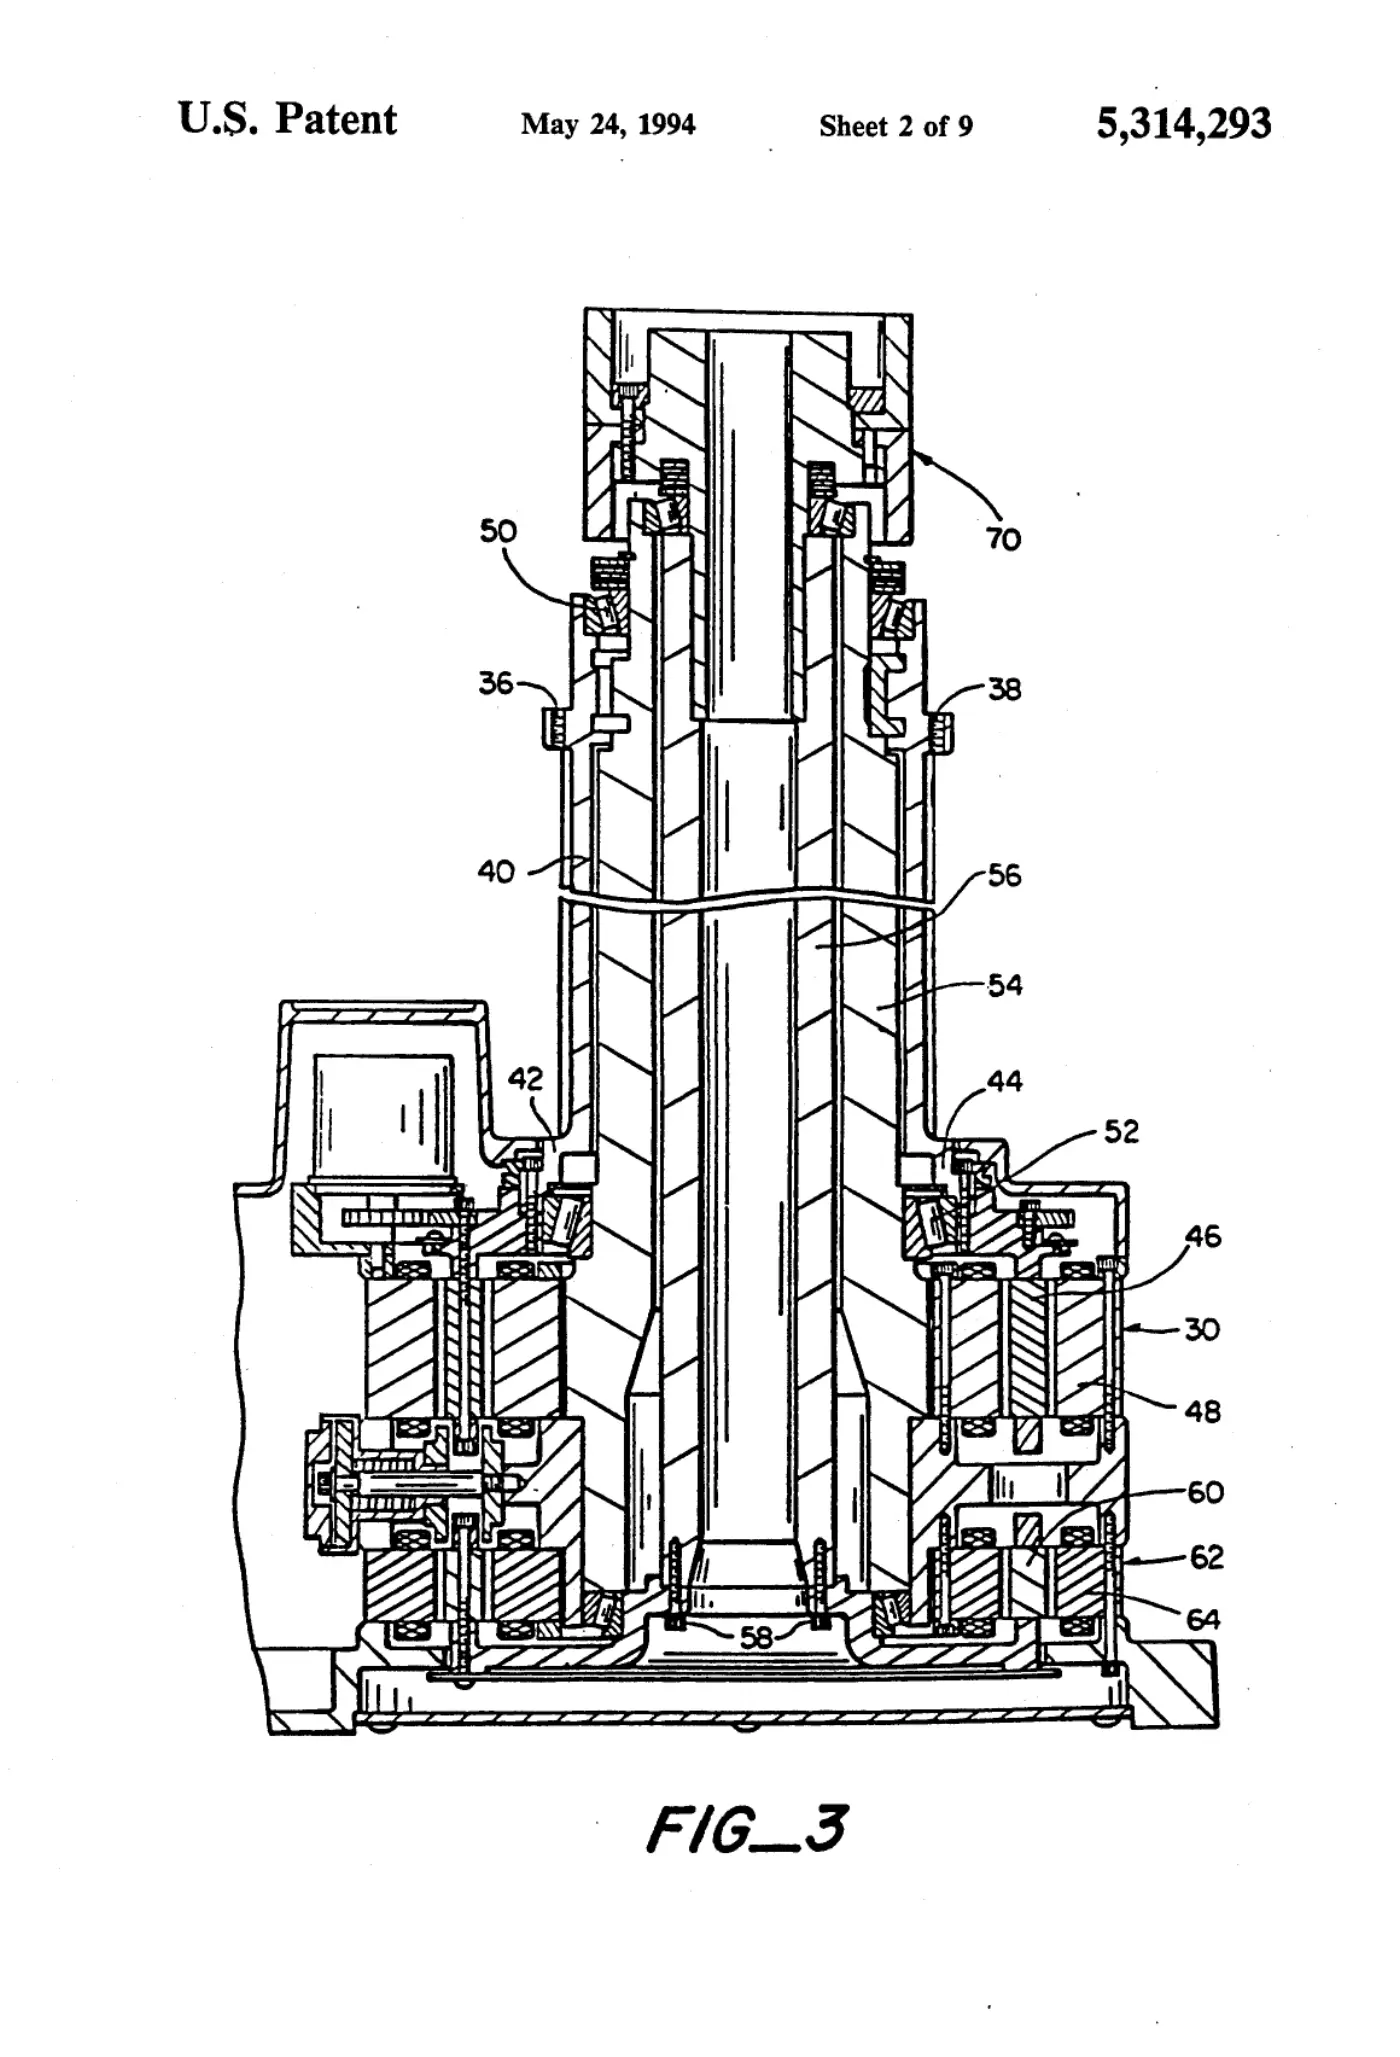
[0002]Sheet 2.
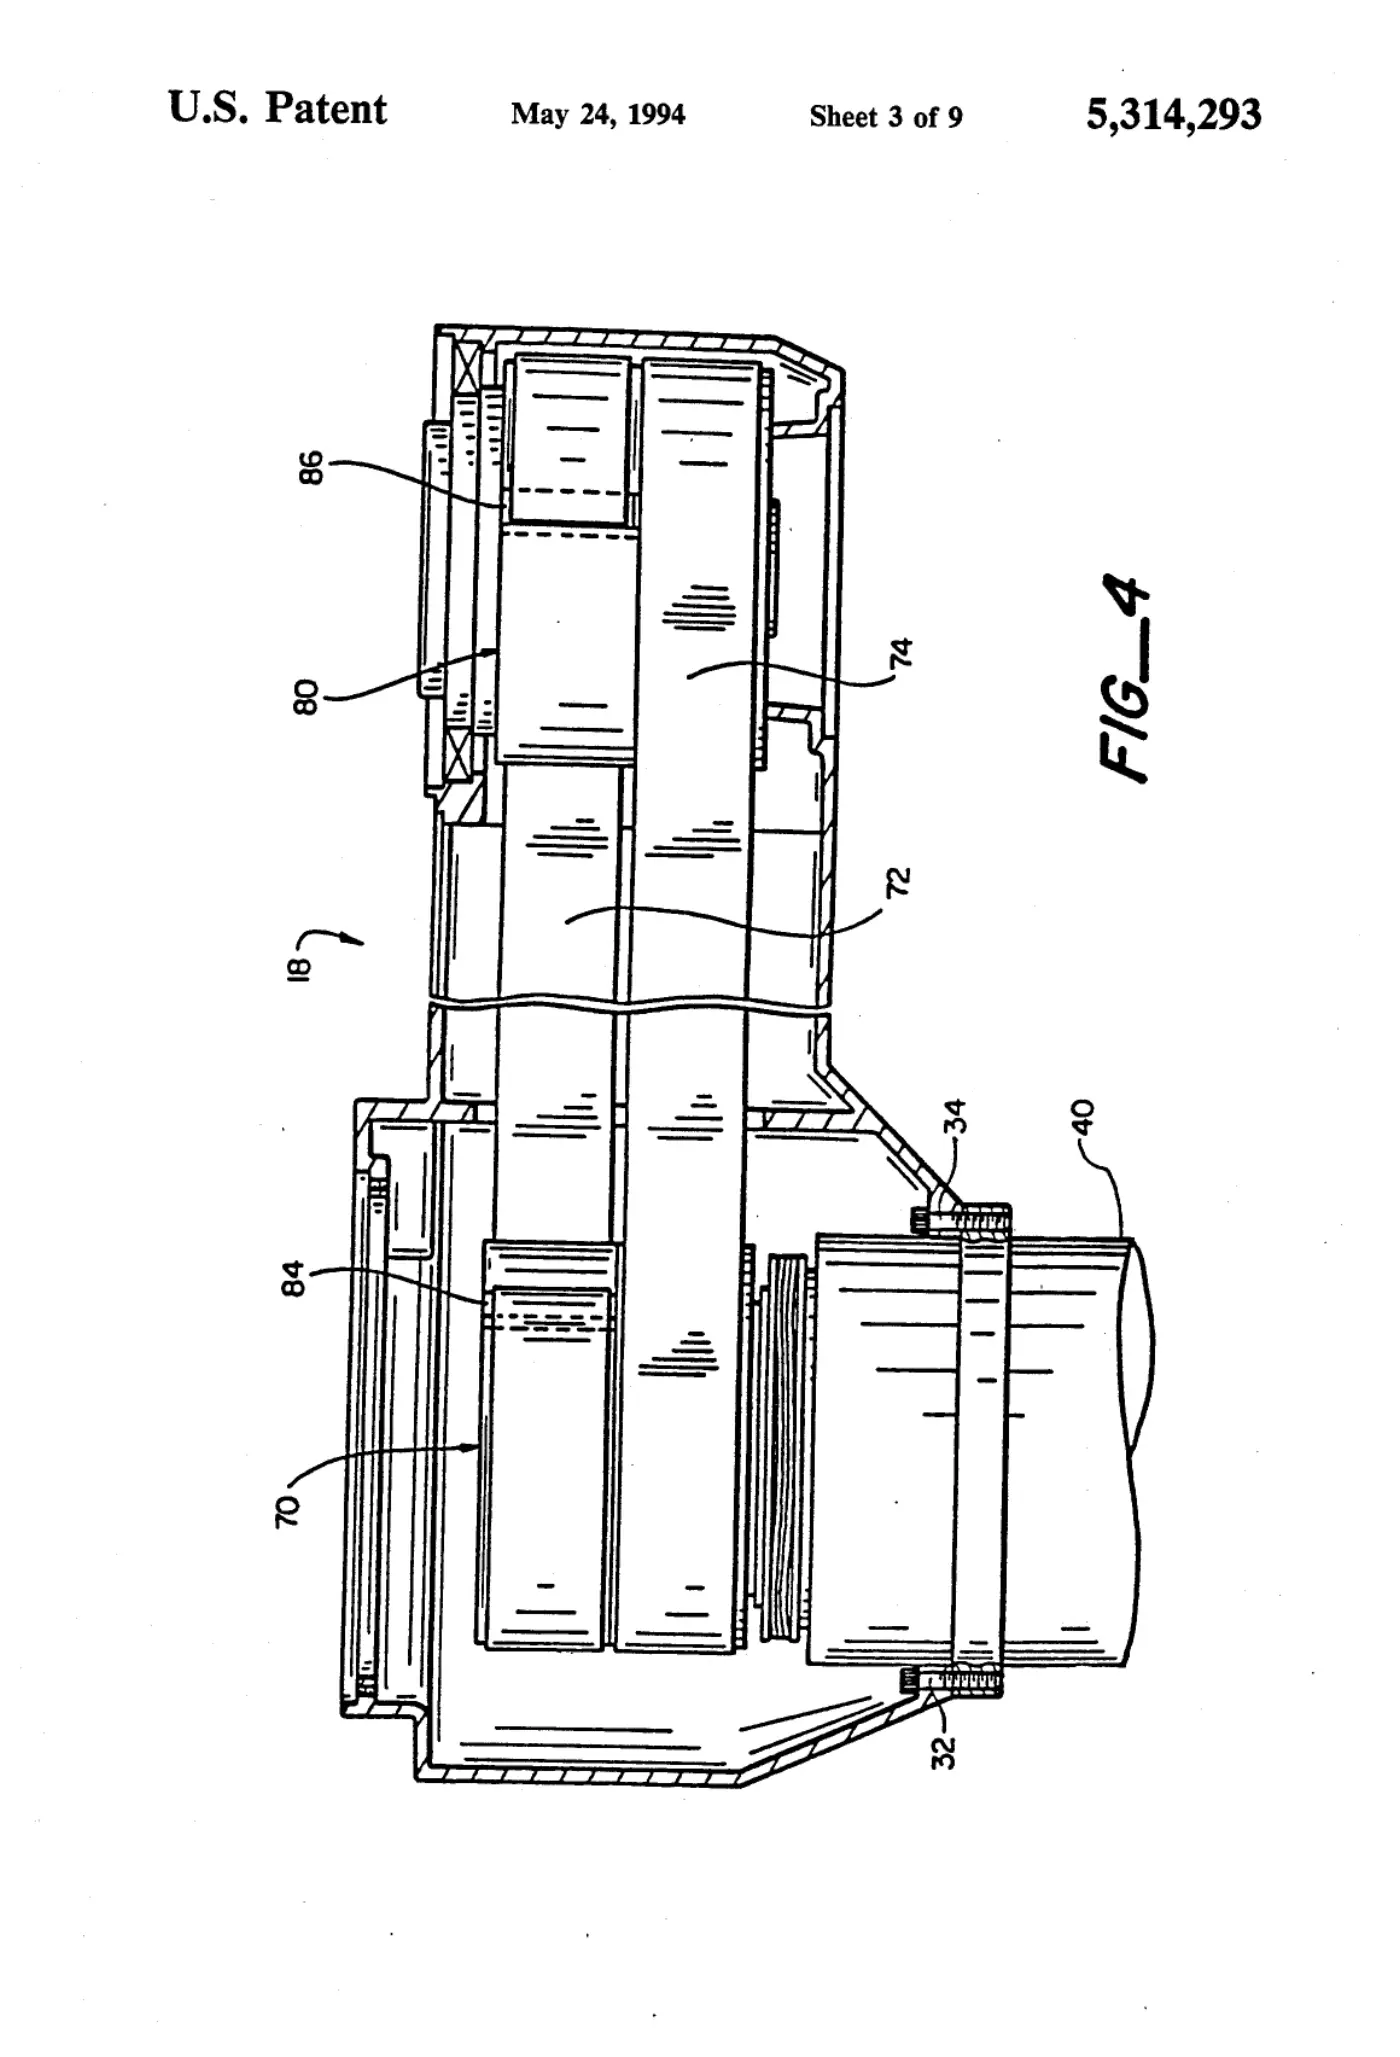
[0003]Sheet 3.
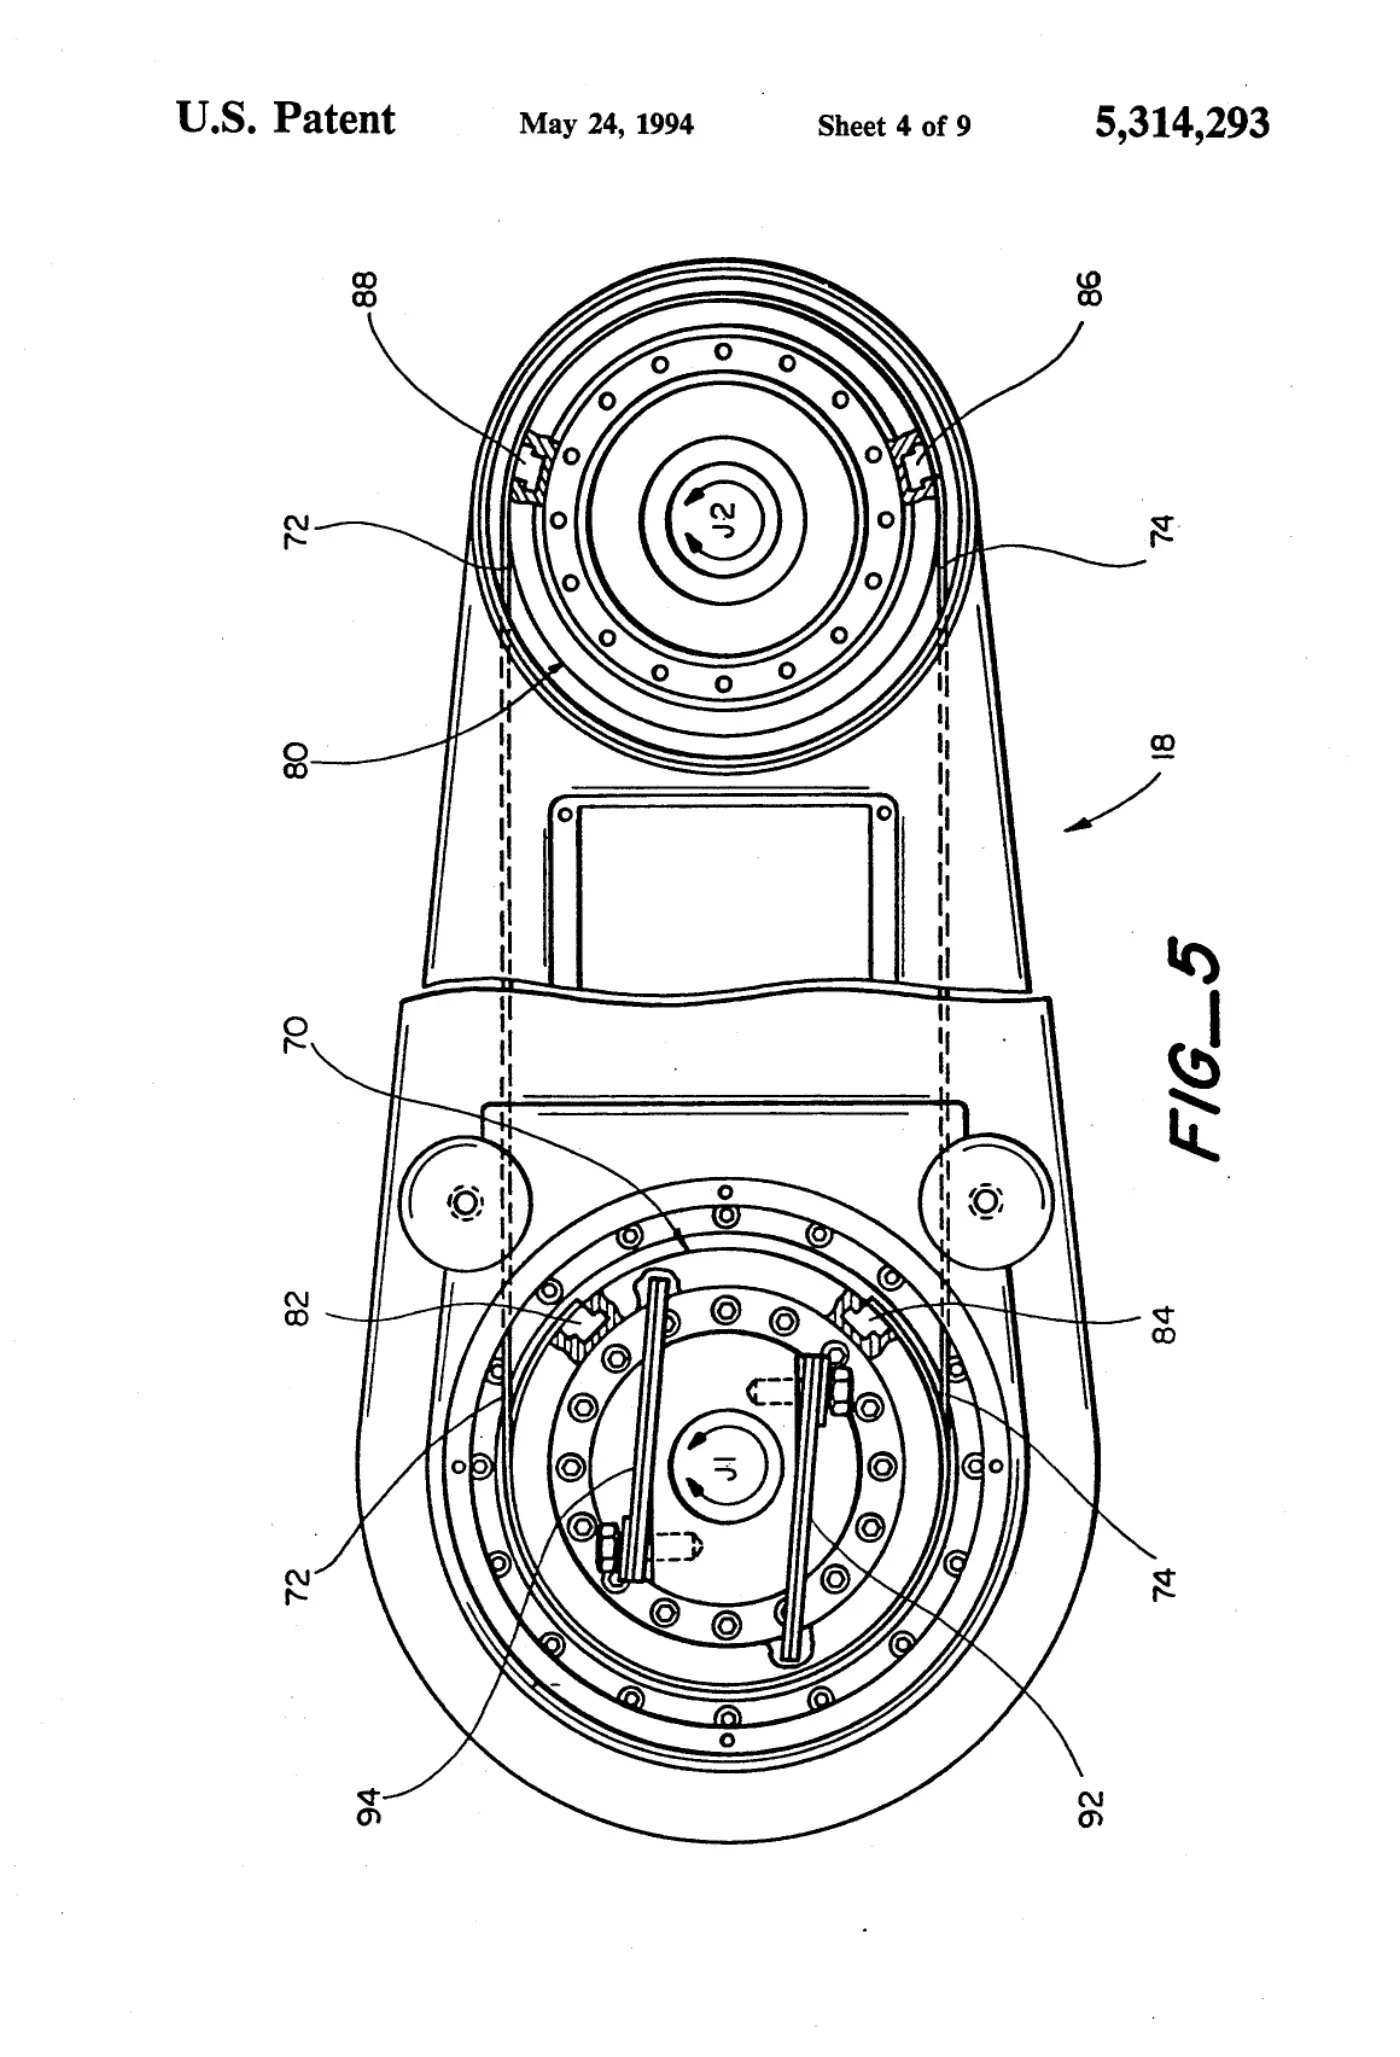
[0004]Sheet 4.
[0005]Sheet 5.
[0006]Sheet 6.
[0007]Sheet 7.
[0008]Sheet 8.
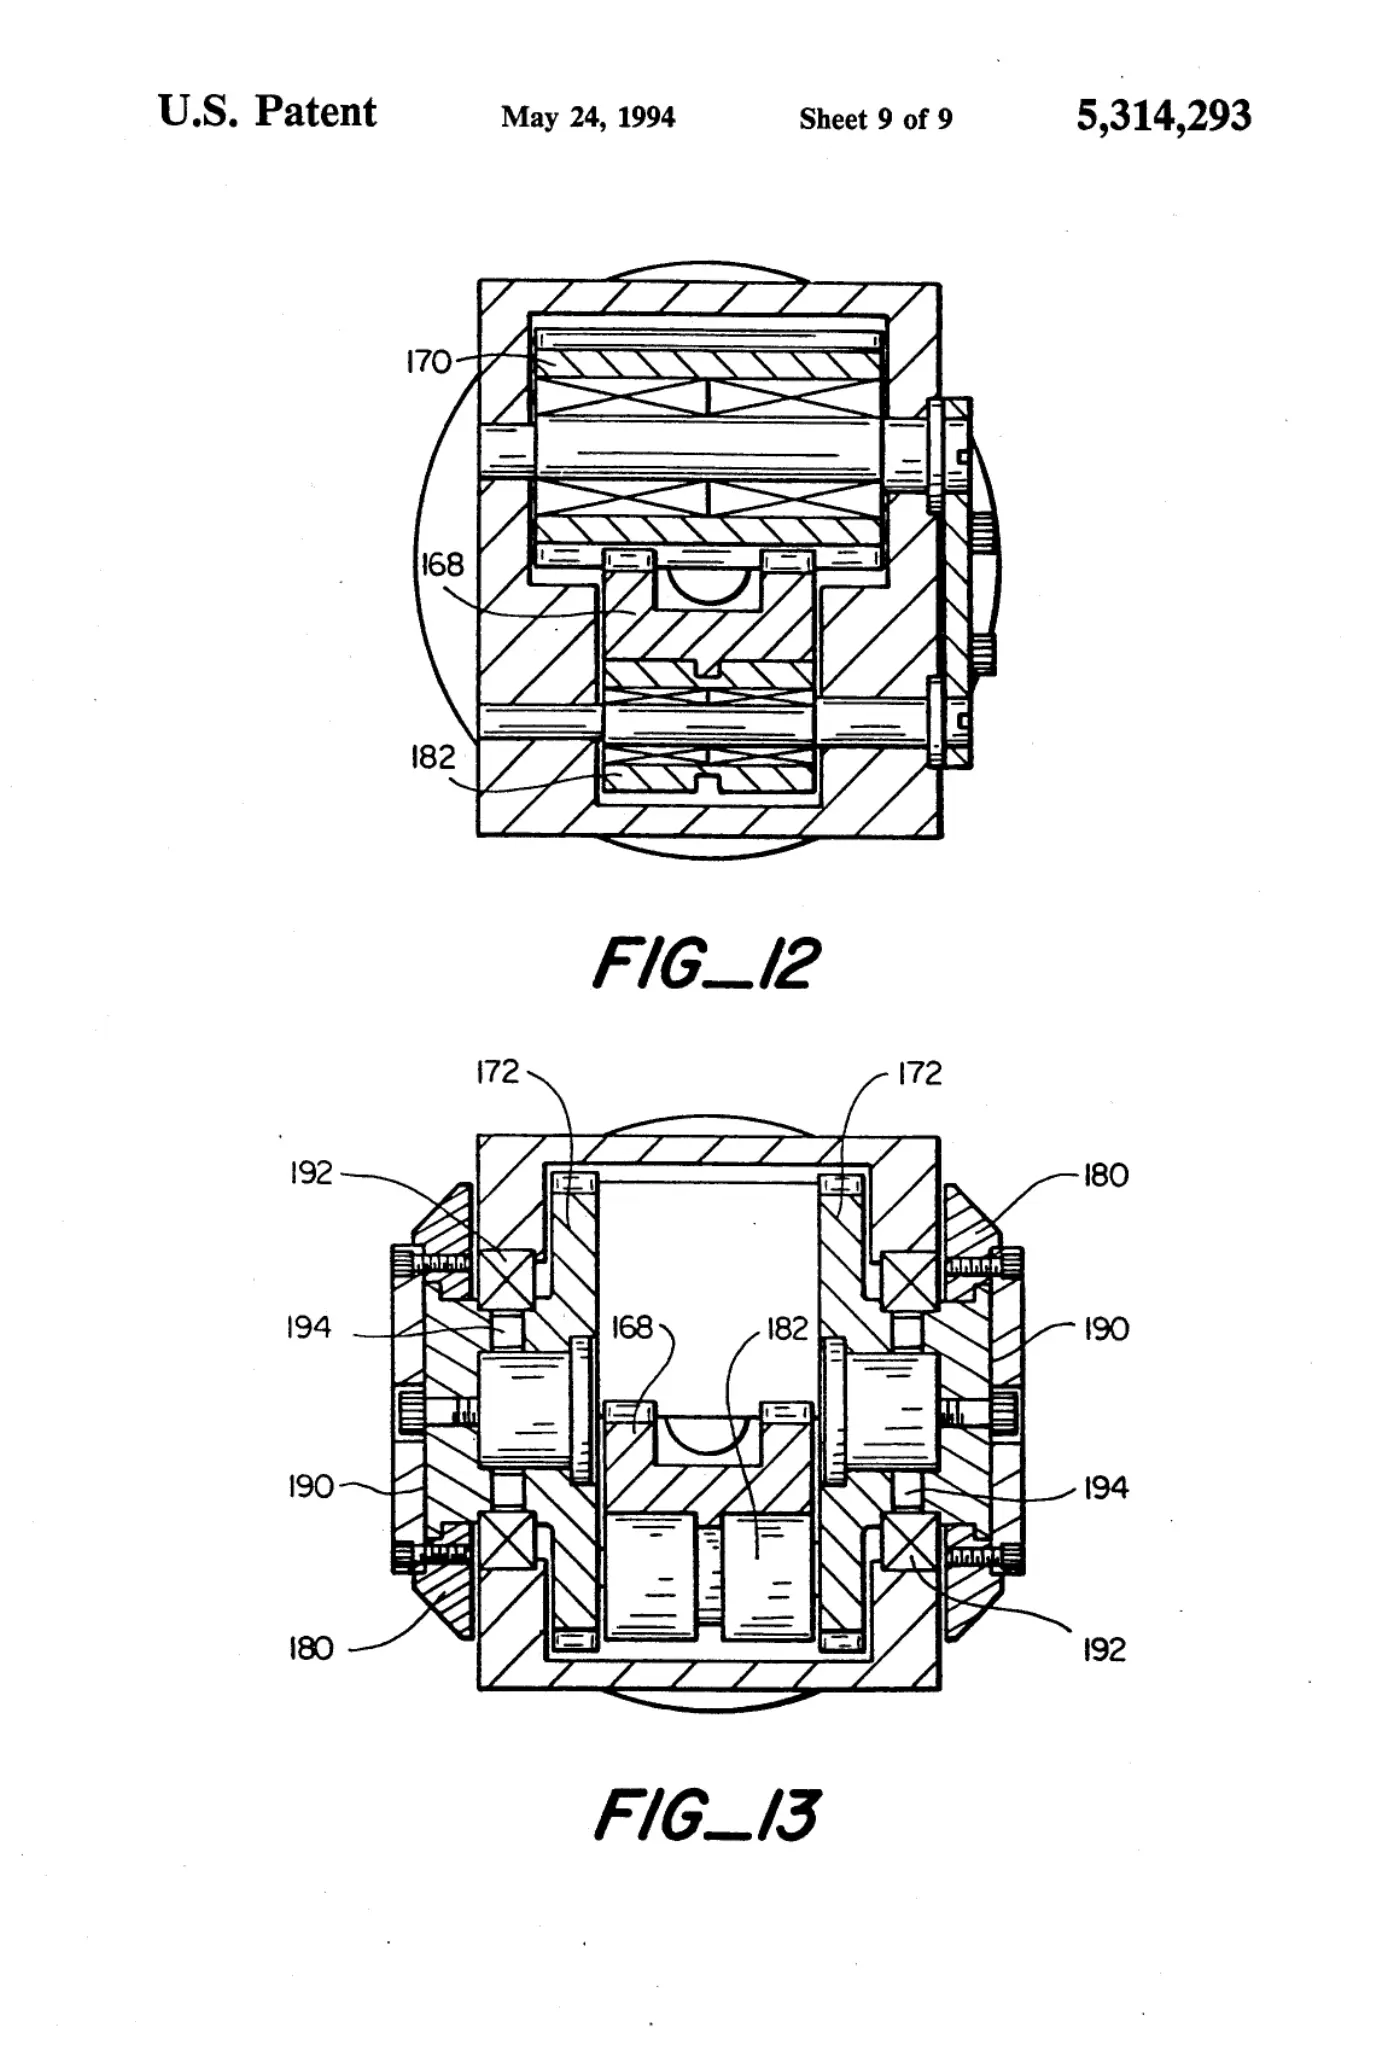
[0009]Sheet 9.
Publication information
Citation
OpenTechnical Publication OT-2026-000003346, “Direct drive robotic system,” published September 15, 2026 at 20:13:35 UTC, https://opentechnical.org/p/OT-2026-000003346.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.