OT-2026-000003354
Motorized rotary joint and method of constructing a modular robot utilizing same
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003354
- Classification
- Robotics & Automation › Robot Architectures
- Assignee
- FANUC ROBOTICS NORTH AMERICA
- Original source
- US-5293107-A, the United States Patent and Trademark Office, 8 March 1994
- Document SHA-256
- 037c3e9eb005f92e3340ecc53d8c9709f21b5345149a100f3704faeb5a59b723
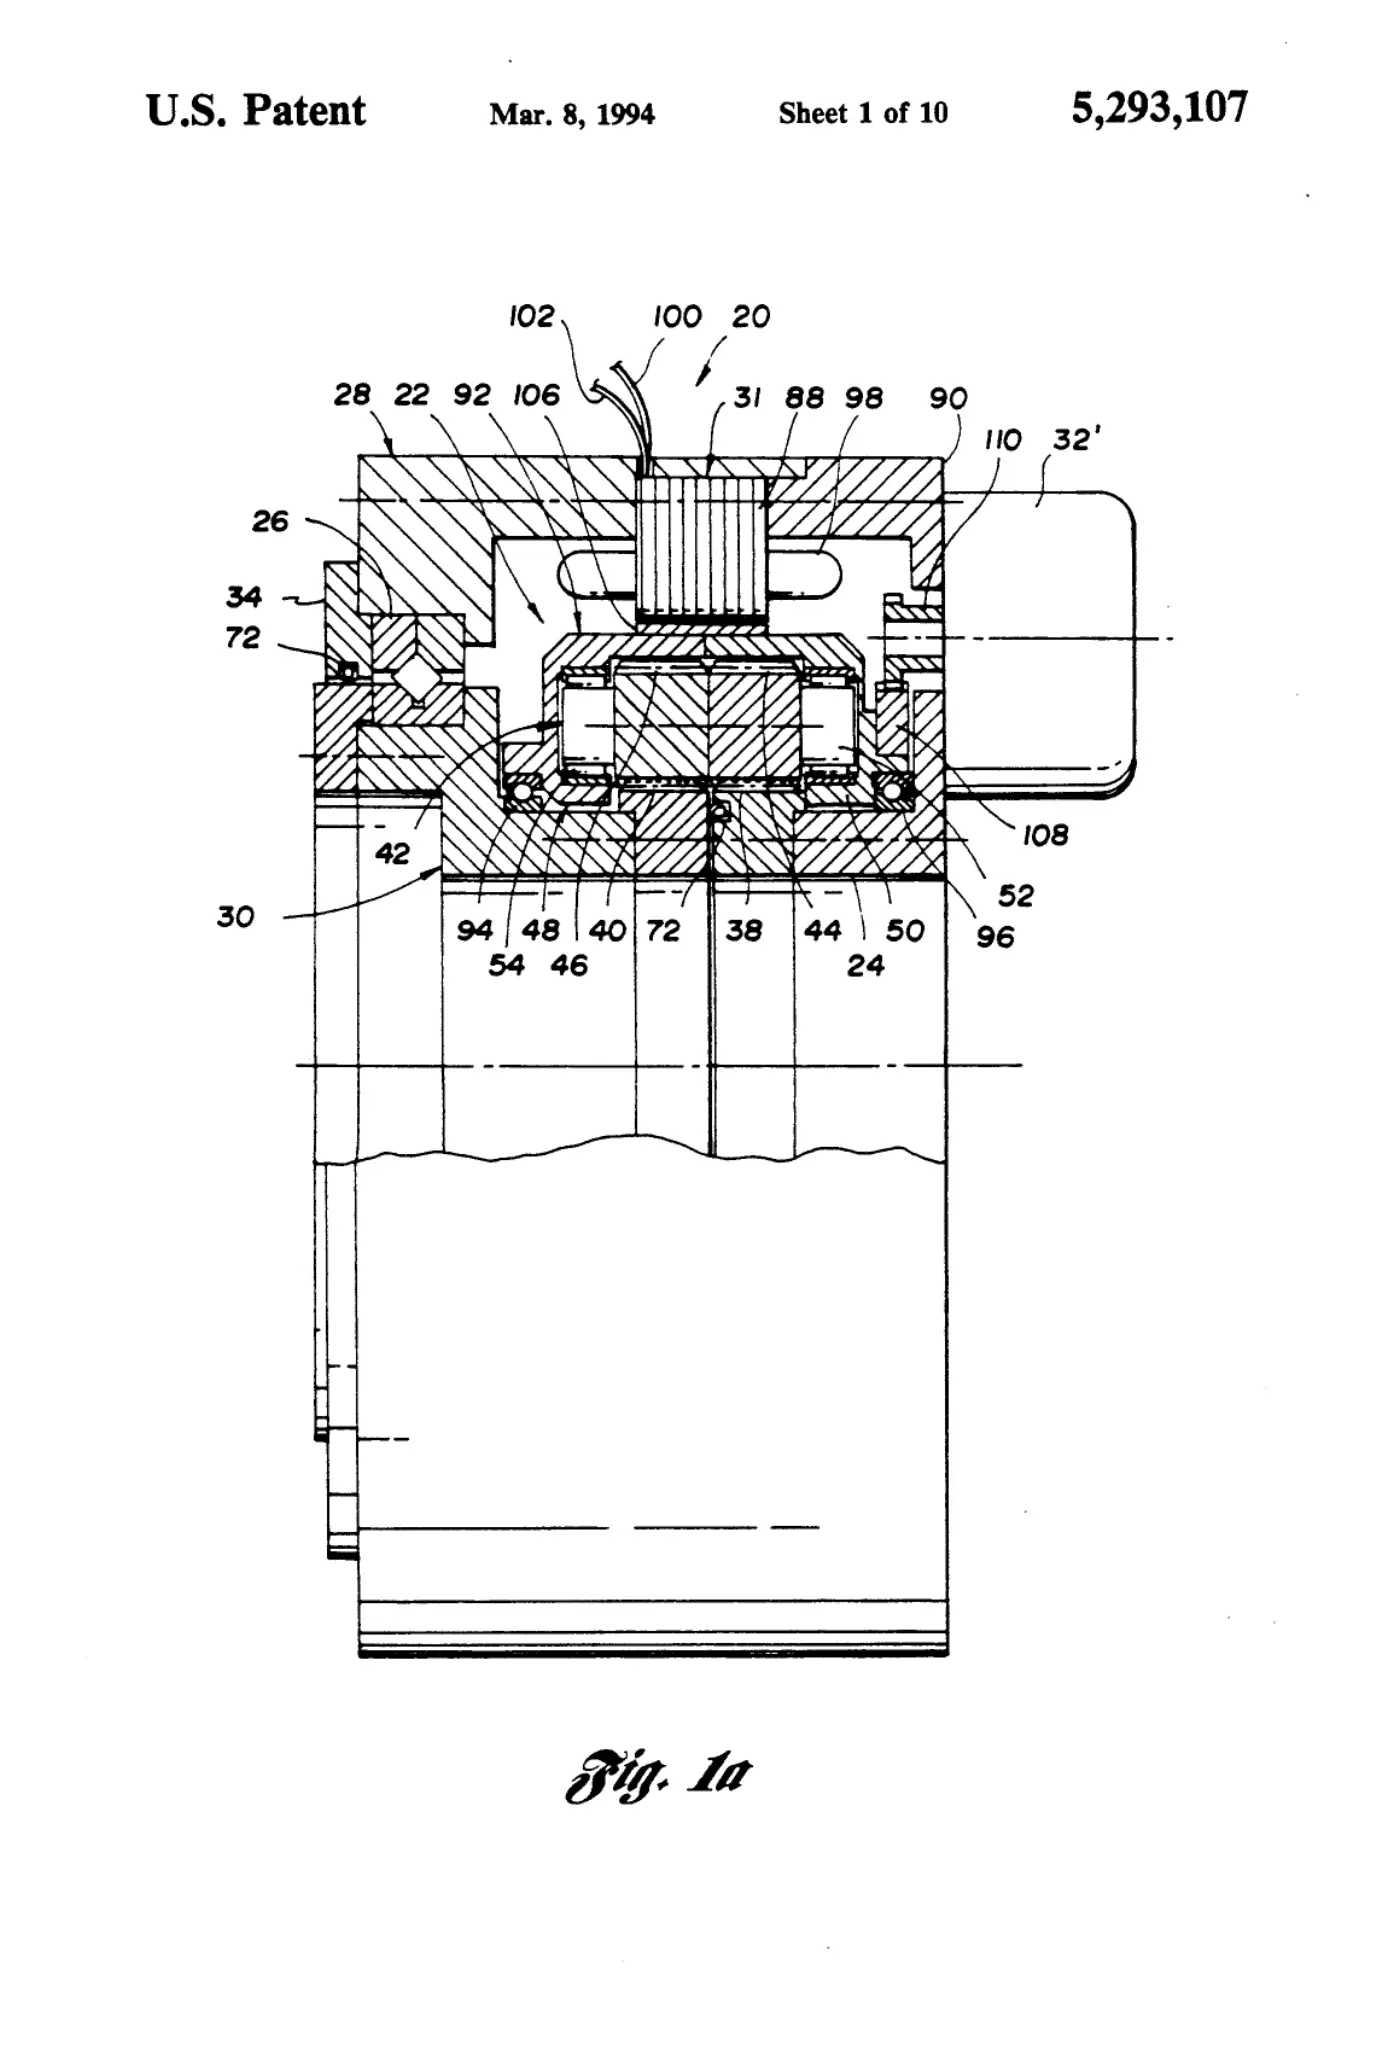
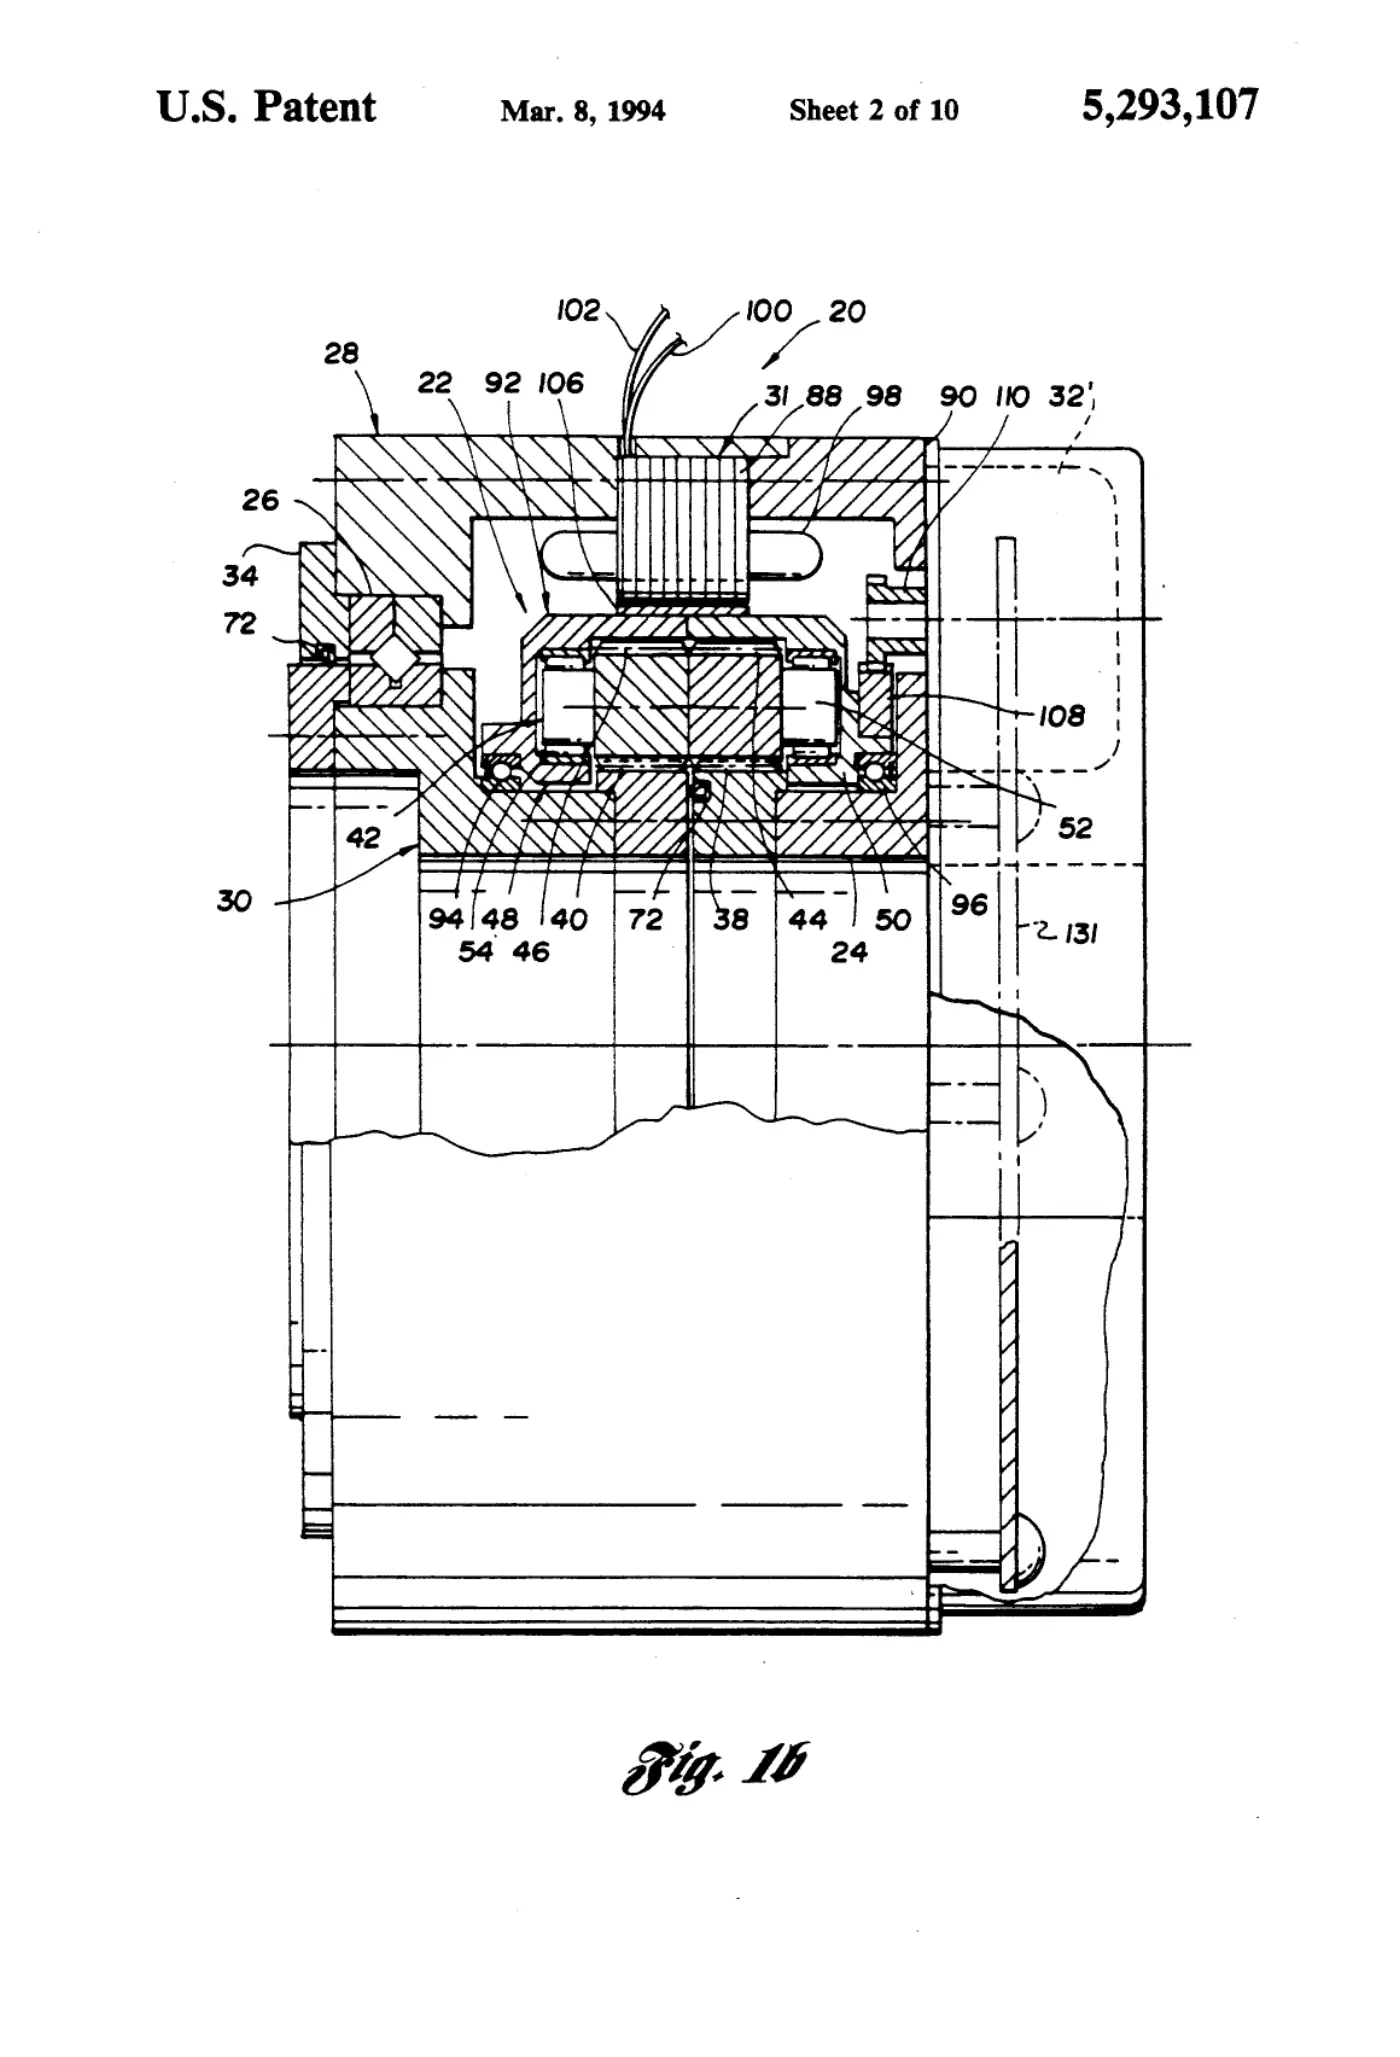
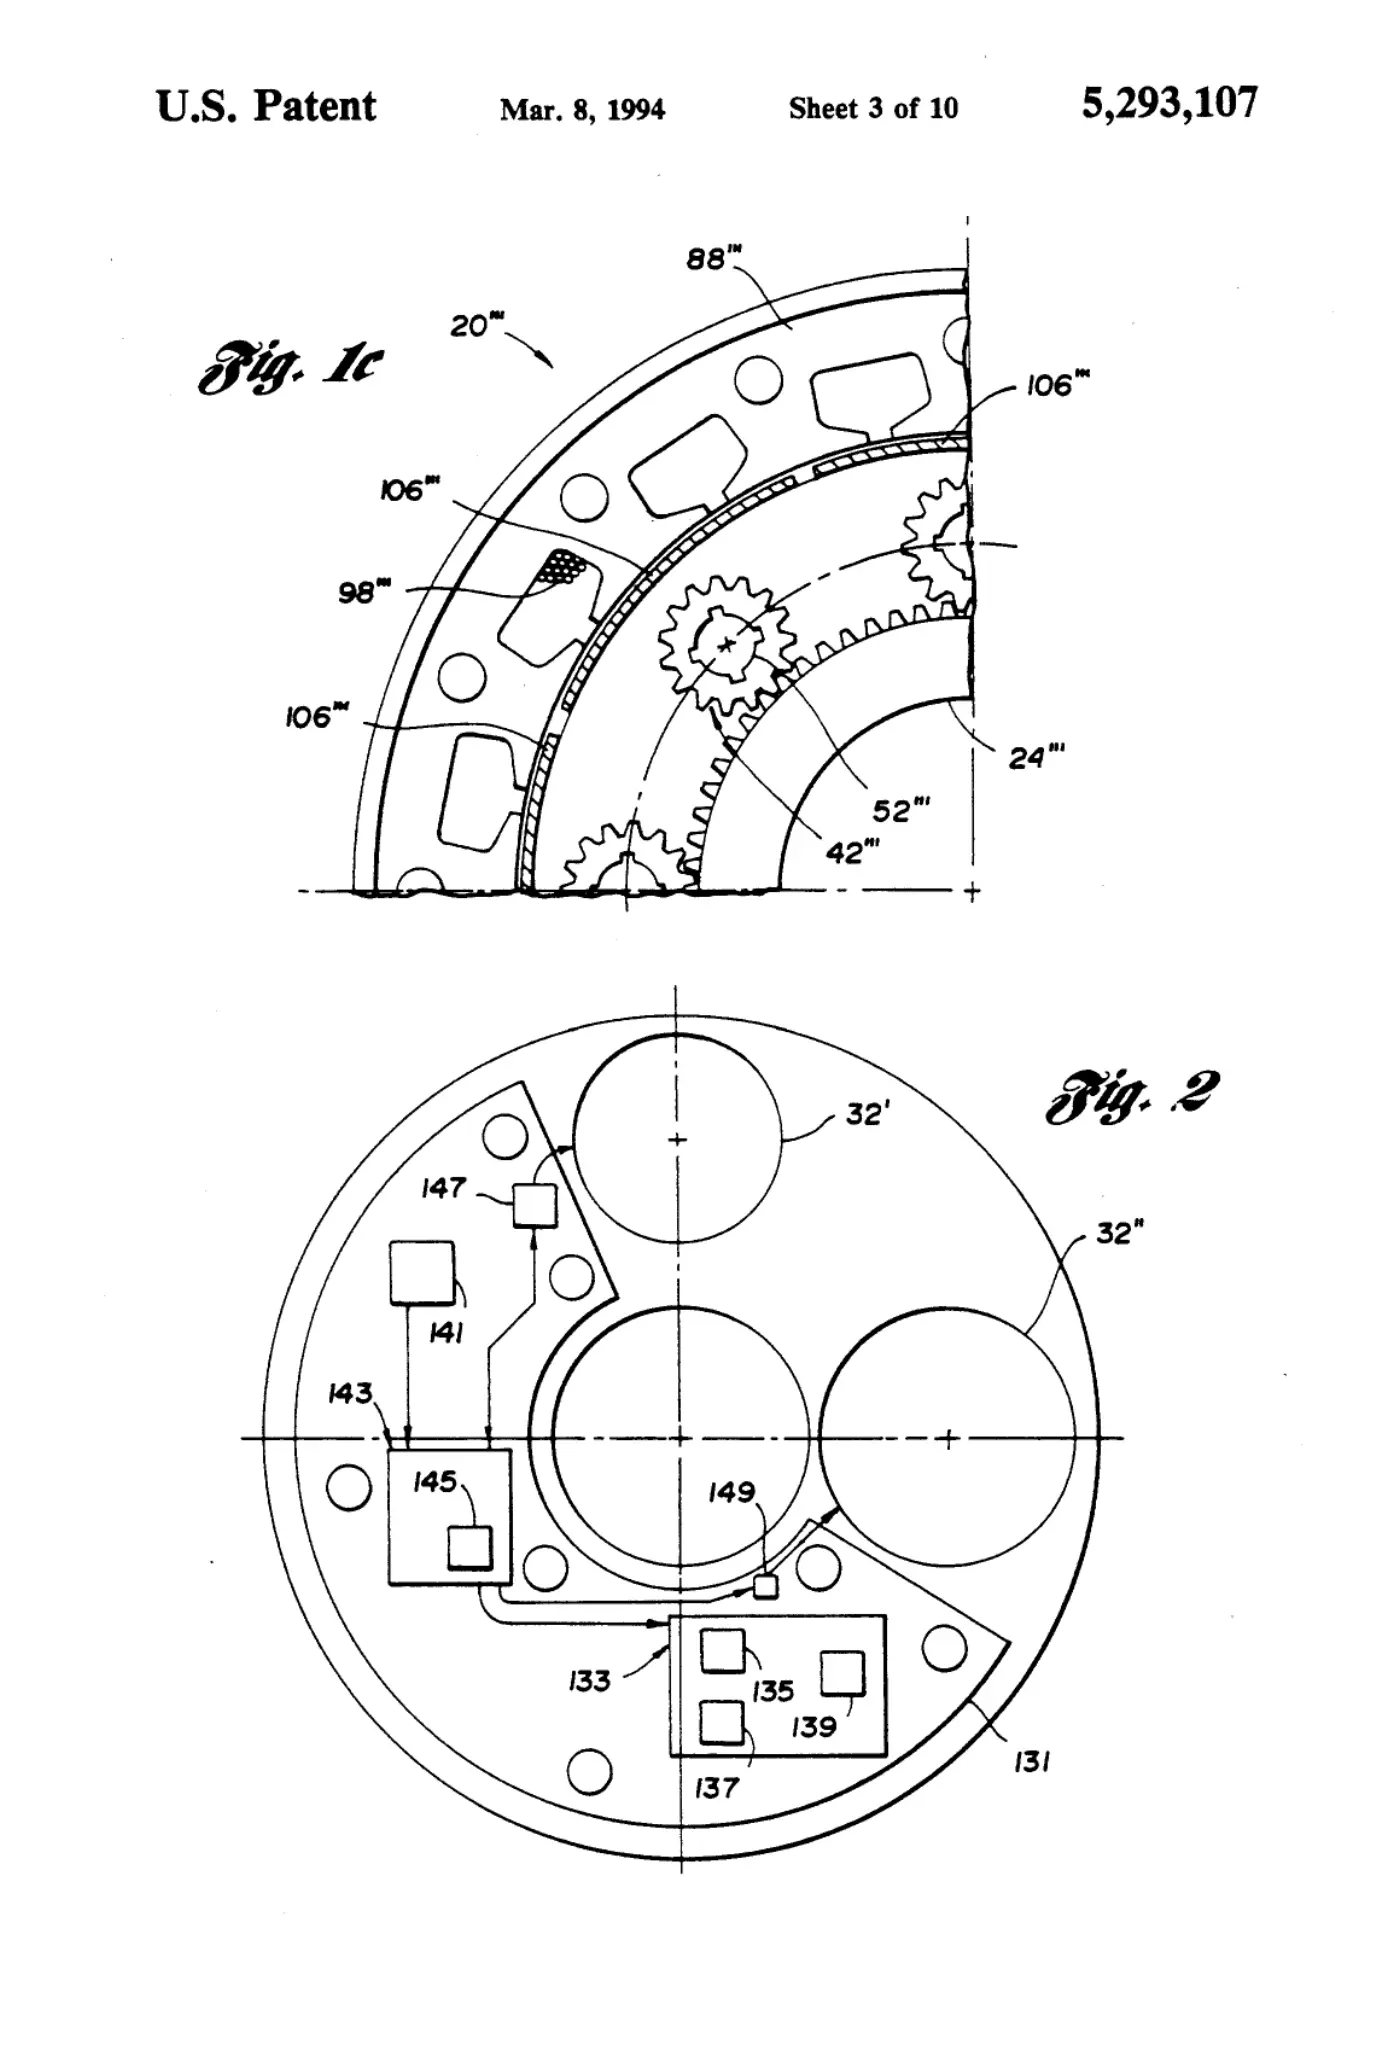
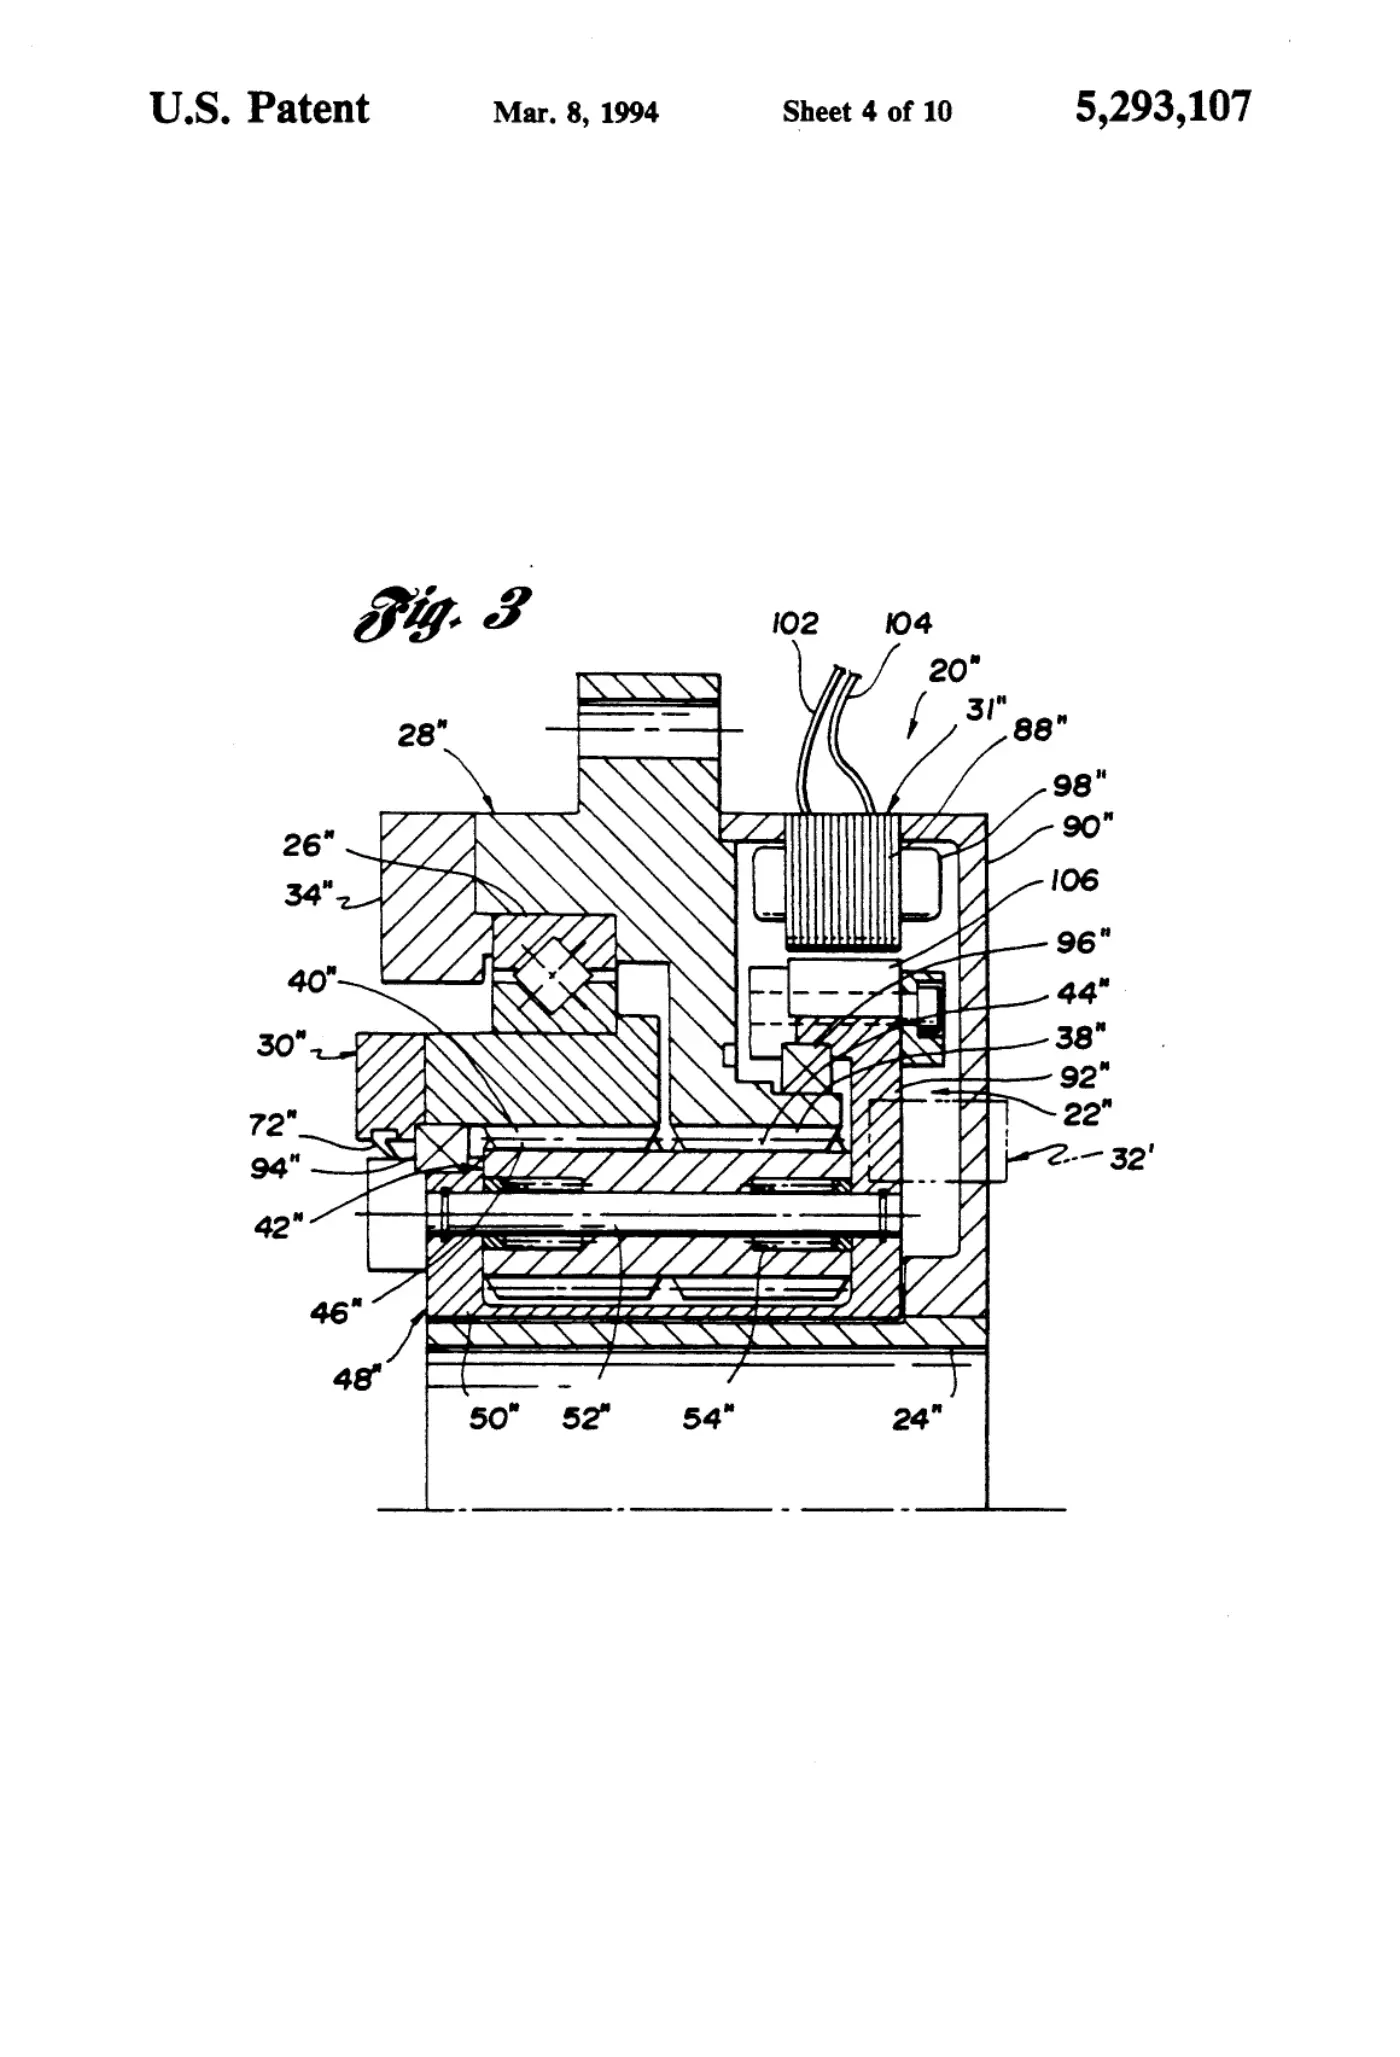
A motorized rotary joint for robots integrates a joint bearing with a power transmission, such as a planetary type speed reducer, and provides a large central hole for passing electric and service lines therethrough. The rotary joint includes a built-in rotor and stator arrangement within the same joint housing structure, thus allowing the electric motor to share the same bearings and housing structure with the speed reducer. Preferably, the rotor also carries planets of the reducer and the stator is either integral or coupled to a housing of the reducer. The rotary joint also accommodates an encoder, a circuit board having electronic components thereon and a built-in brake to provide a totally integrated, intelligent rotary joint. A method for constructing a modular robot using the rotary joint is also provided, wherein several such rotary joints are coupled to simple structural elements by means of bolted interfaces to construct a multi-joint robot of an articulated structure. Such a modular robot has low cost, is easy to maintain and service, and can be readily and speedily constructed and reconfigured from integrated modular components.
Abstract
A motorized rotary joint for robots integrates a joint bearing with a power transmission, such as a planetary type speed reducer, and provides a large central hole for passing electric and service lines therethrough. The rotary joint includes a built-in rotor and stator arrangement within the same joint housing structure, thus allowing the electric motor to share the same bearings and housing structure with the speed reducer. Preferably, the rotor also carries planets of the reducer and the stator is either integral or coupled to a housing of the reducer. The rotary joint also accommodates an encoder, a circuit board having electronic components thereon and a built-in brake to provide a totally integrated, intelligent rotary joint. A method for constructing a modular robot using the rotary joint is also provided, wherein several such rotary joints are coupled to simple structural elements by means of bolted interfaces to construct a multi-joint robot of an articulated structure. Such a modular robot has low cost, is easy to maintain and service, and can be readily and speedily constructed and reconfigured from integrated modular components.
1. Drawings
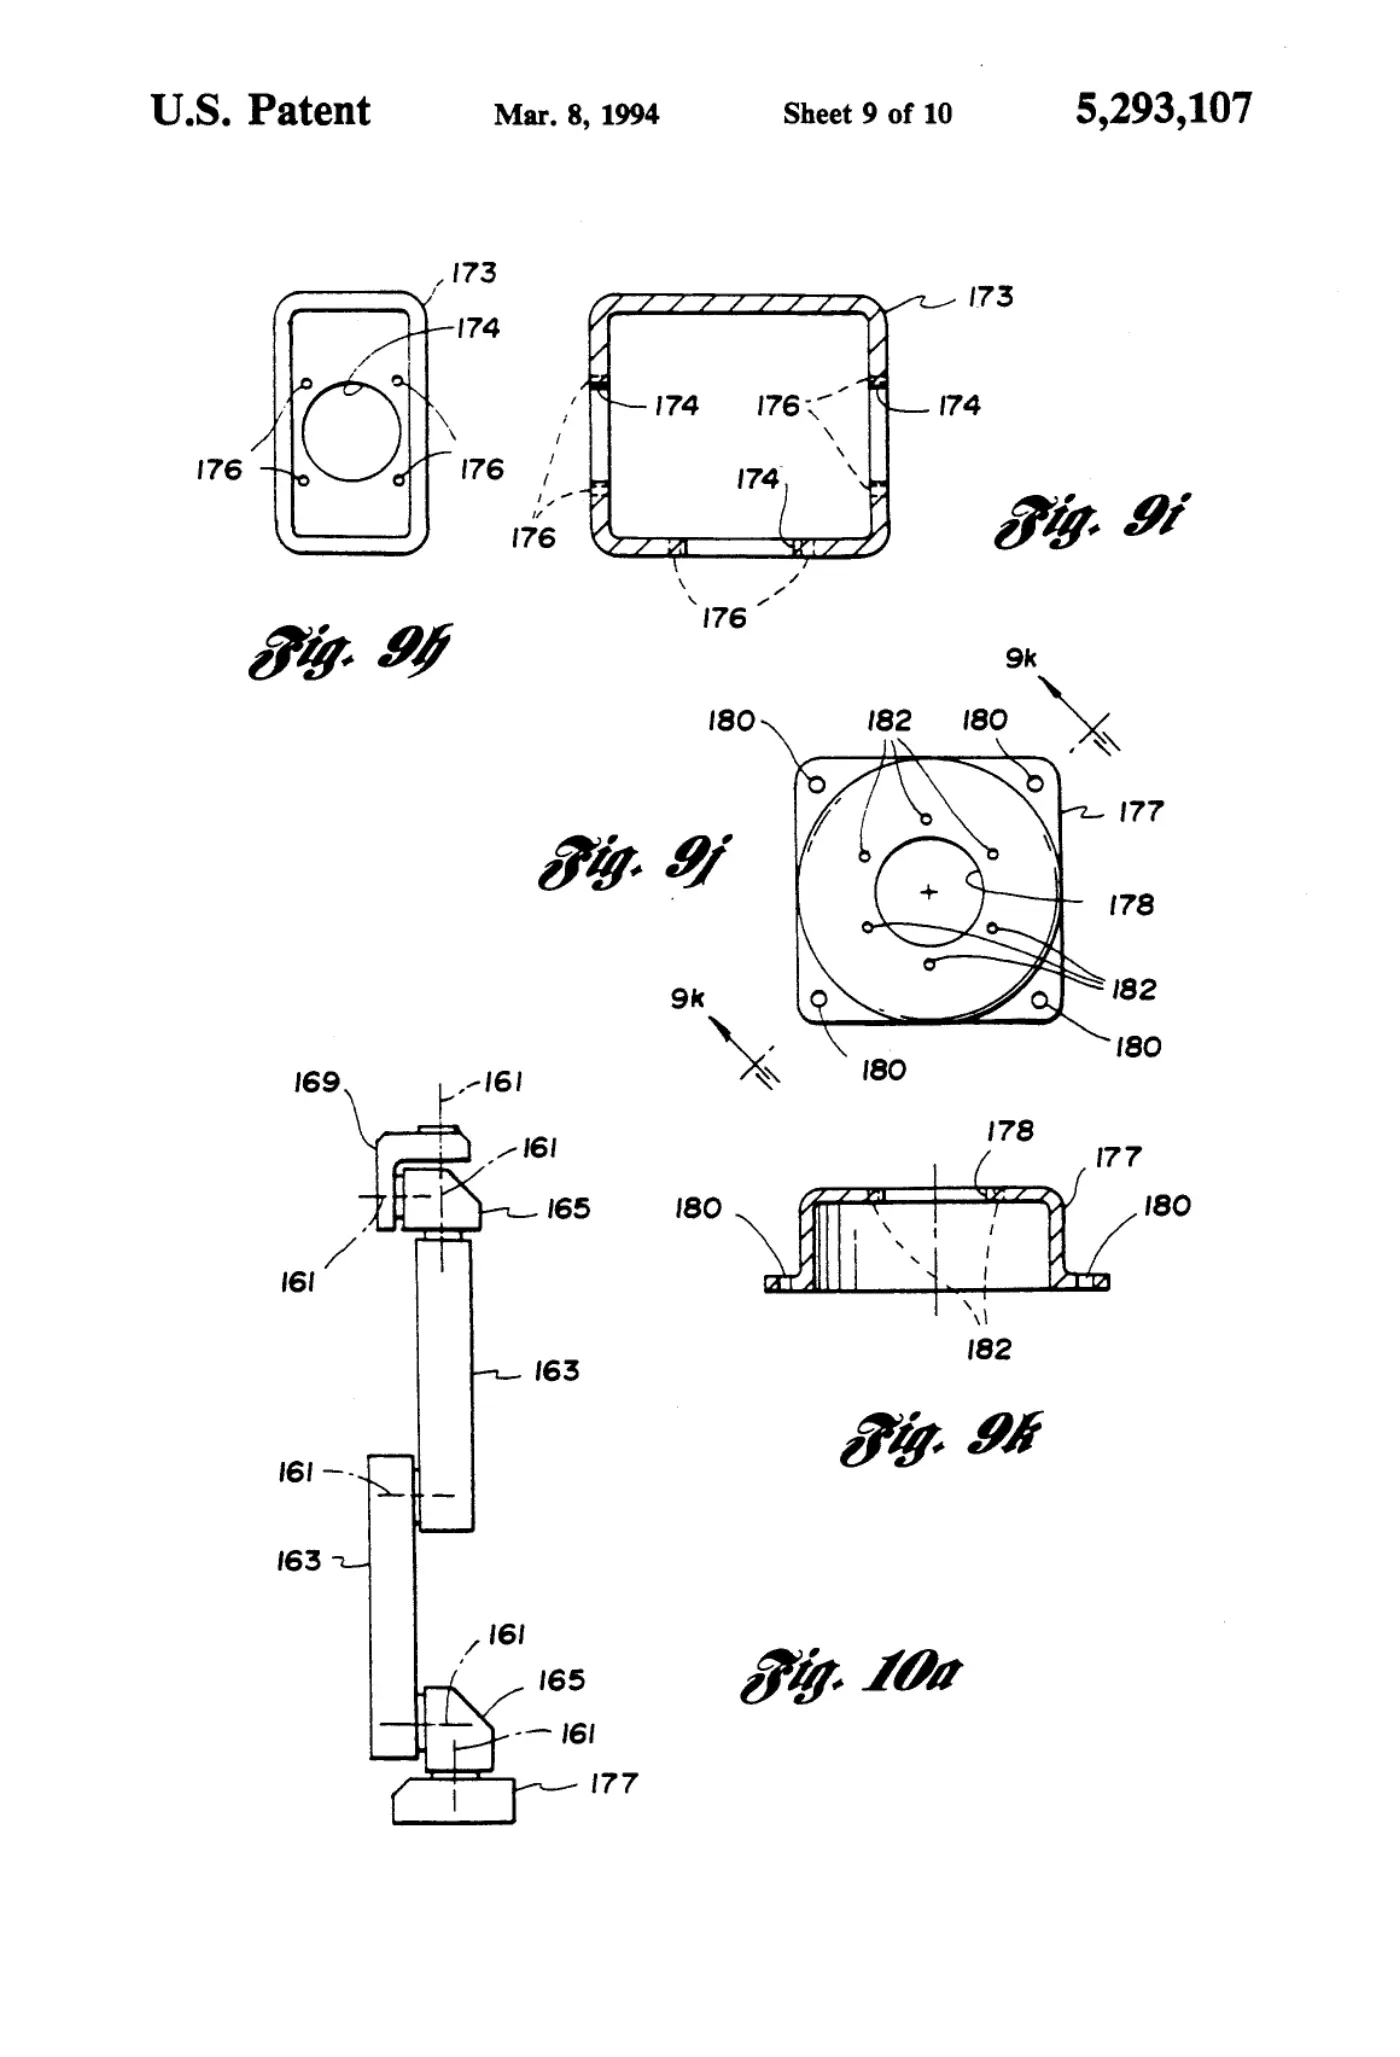
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
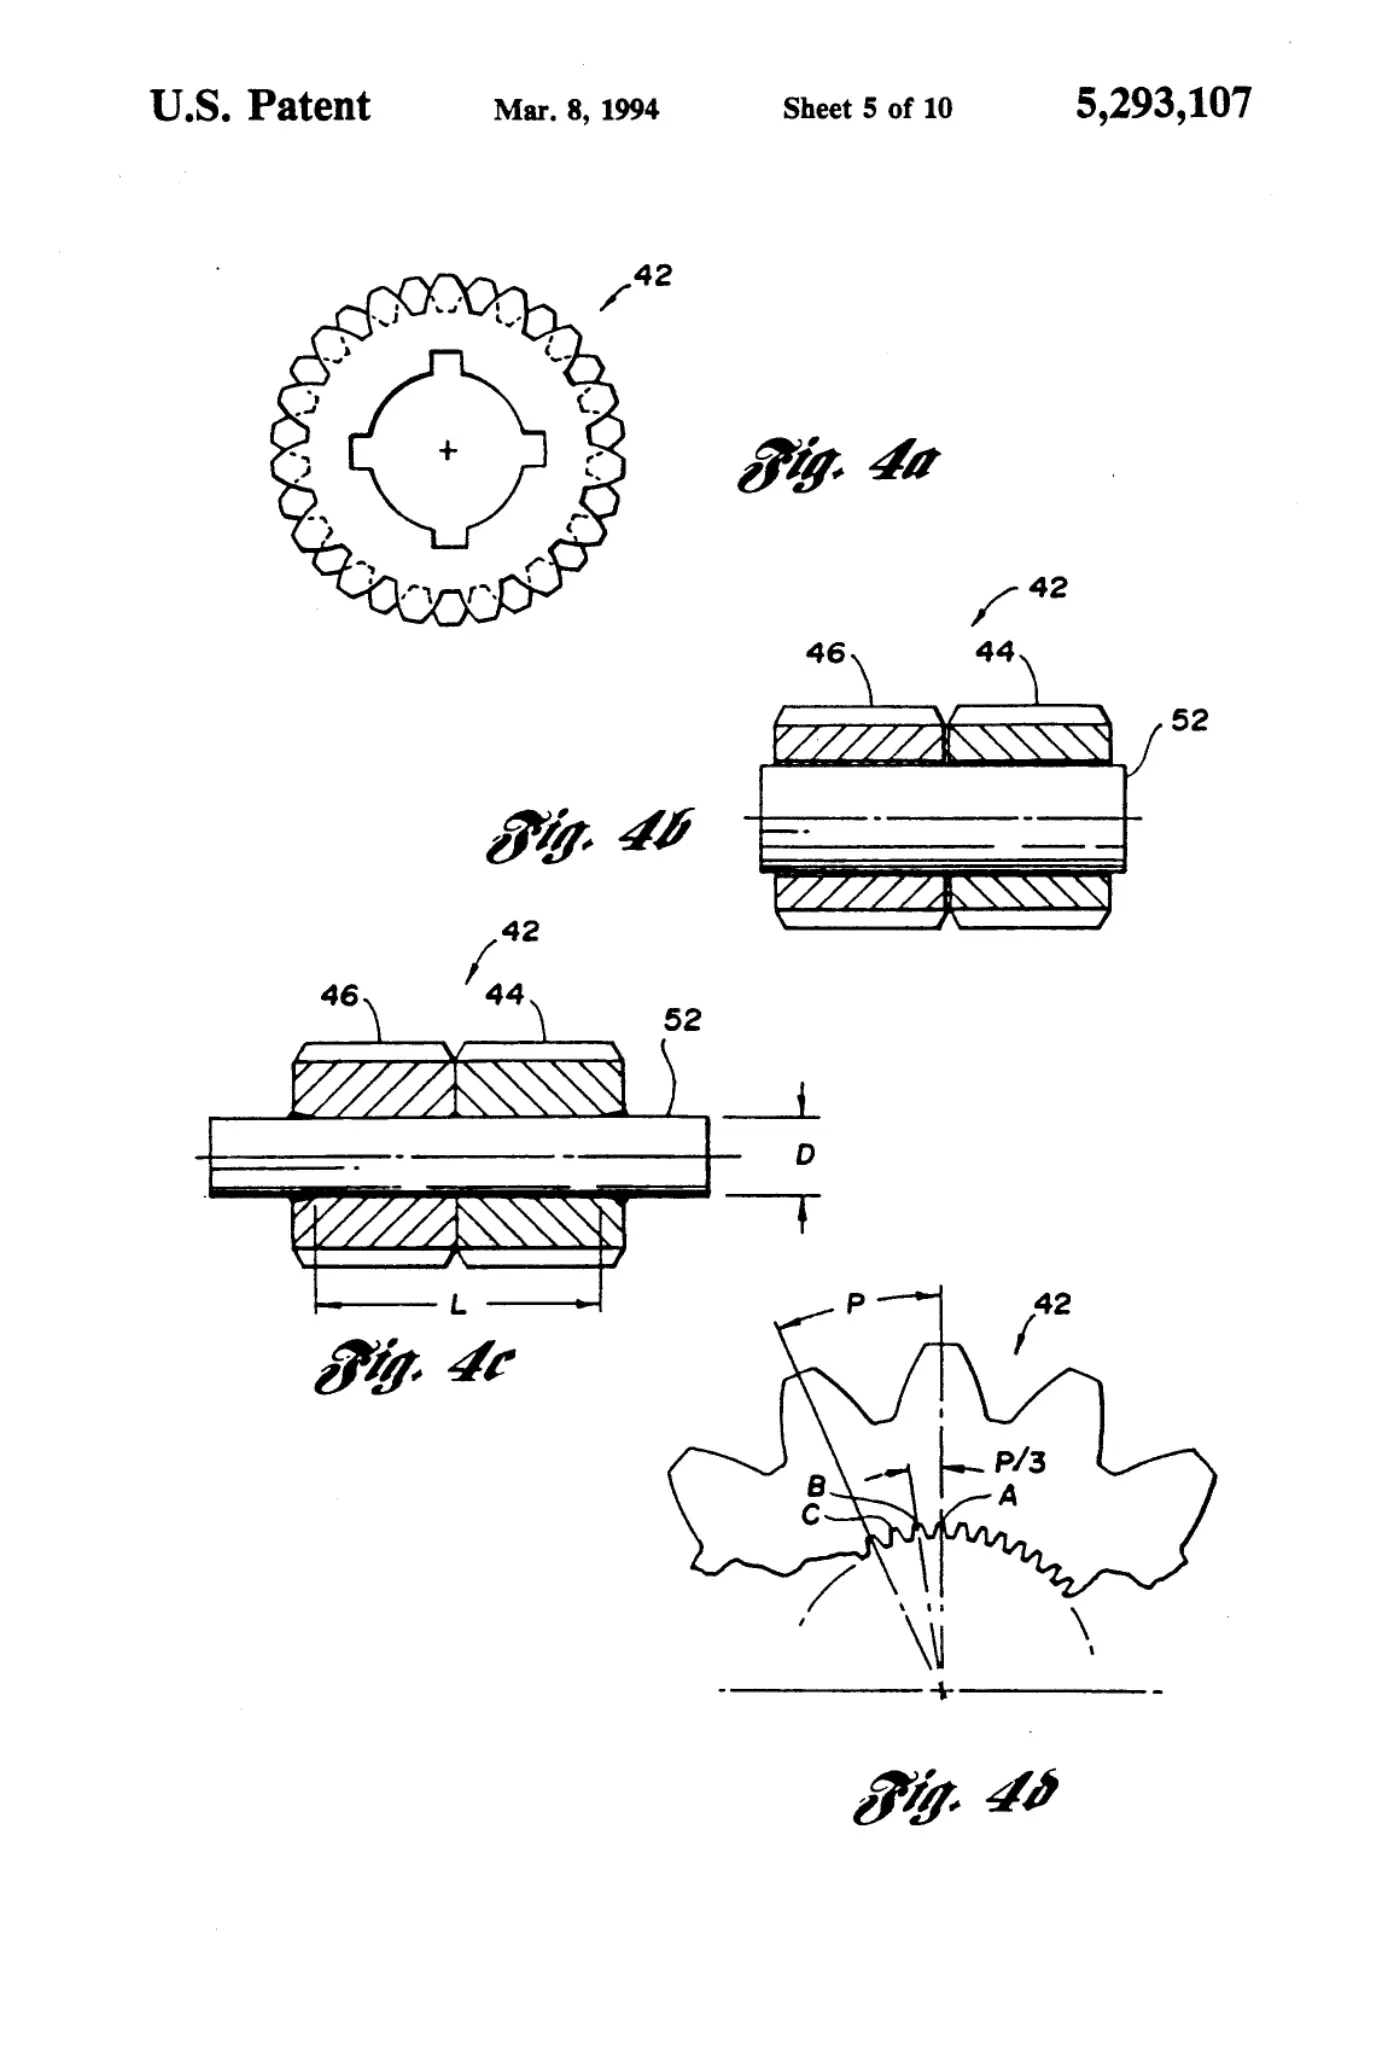
[0005]Sheet 5.
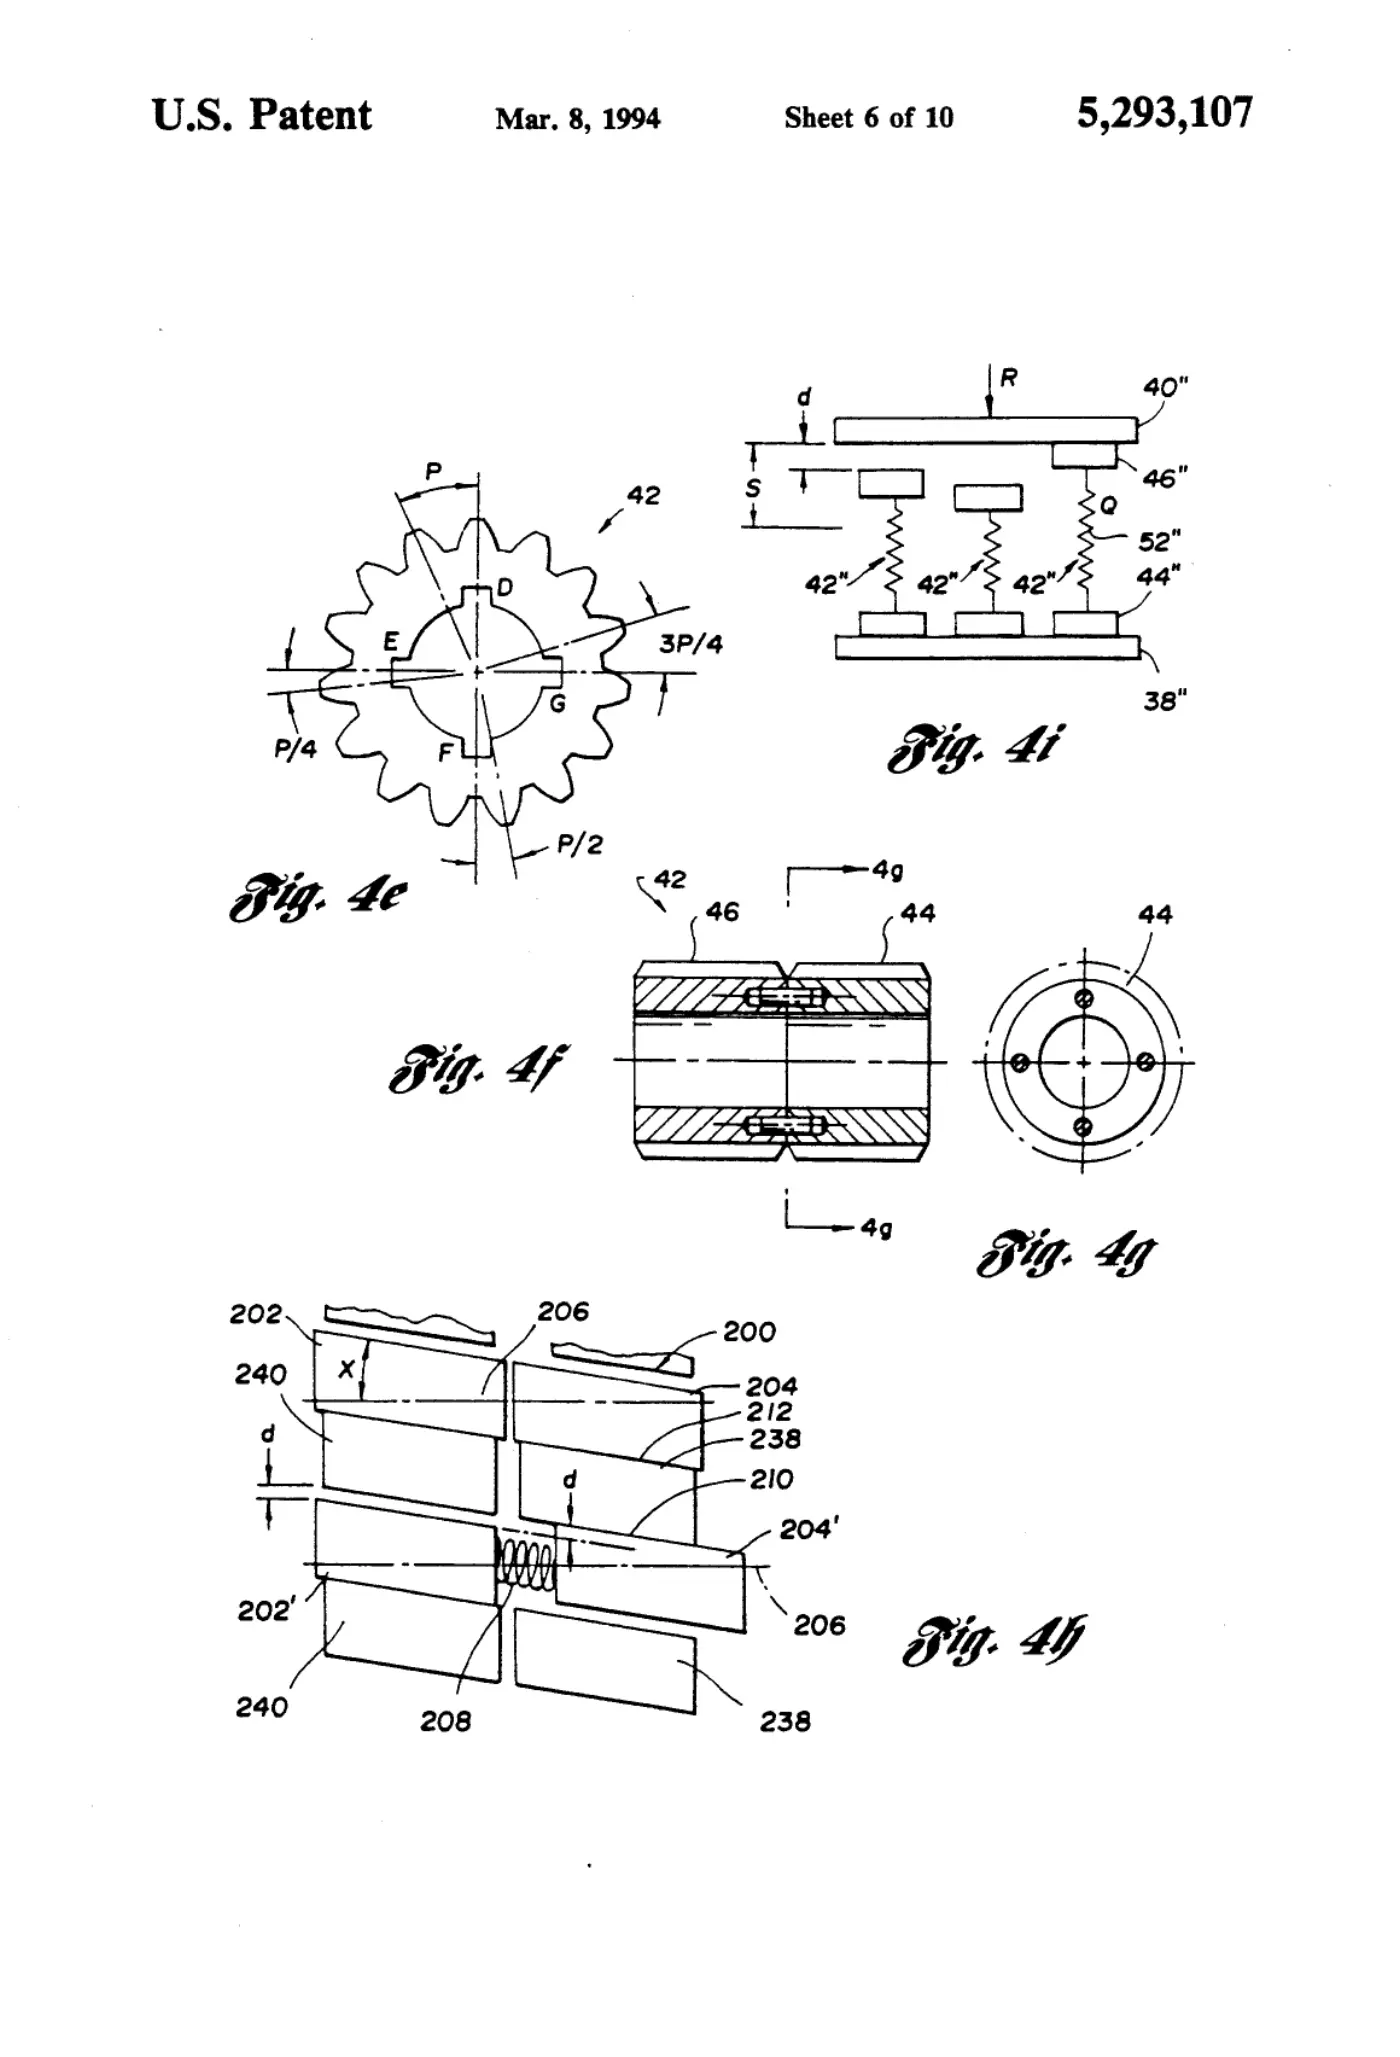
[0006]Sheet 6.
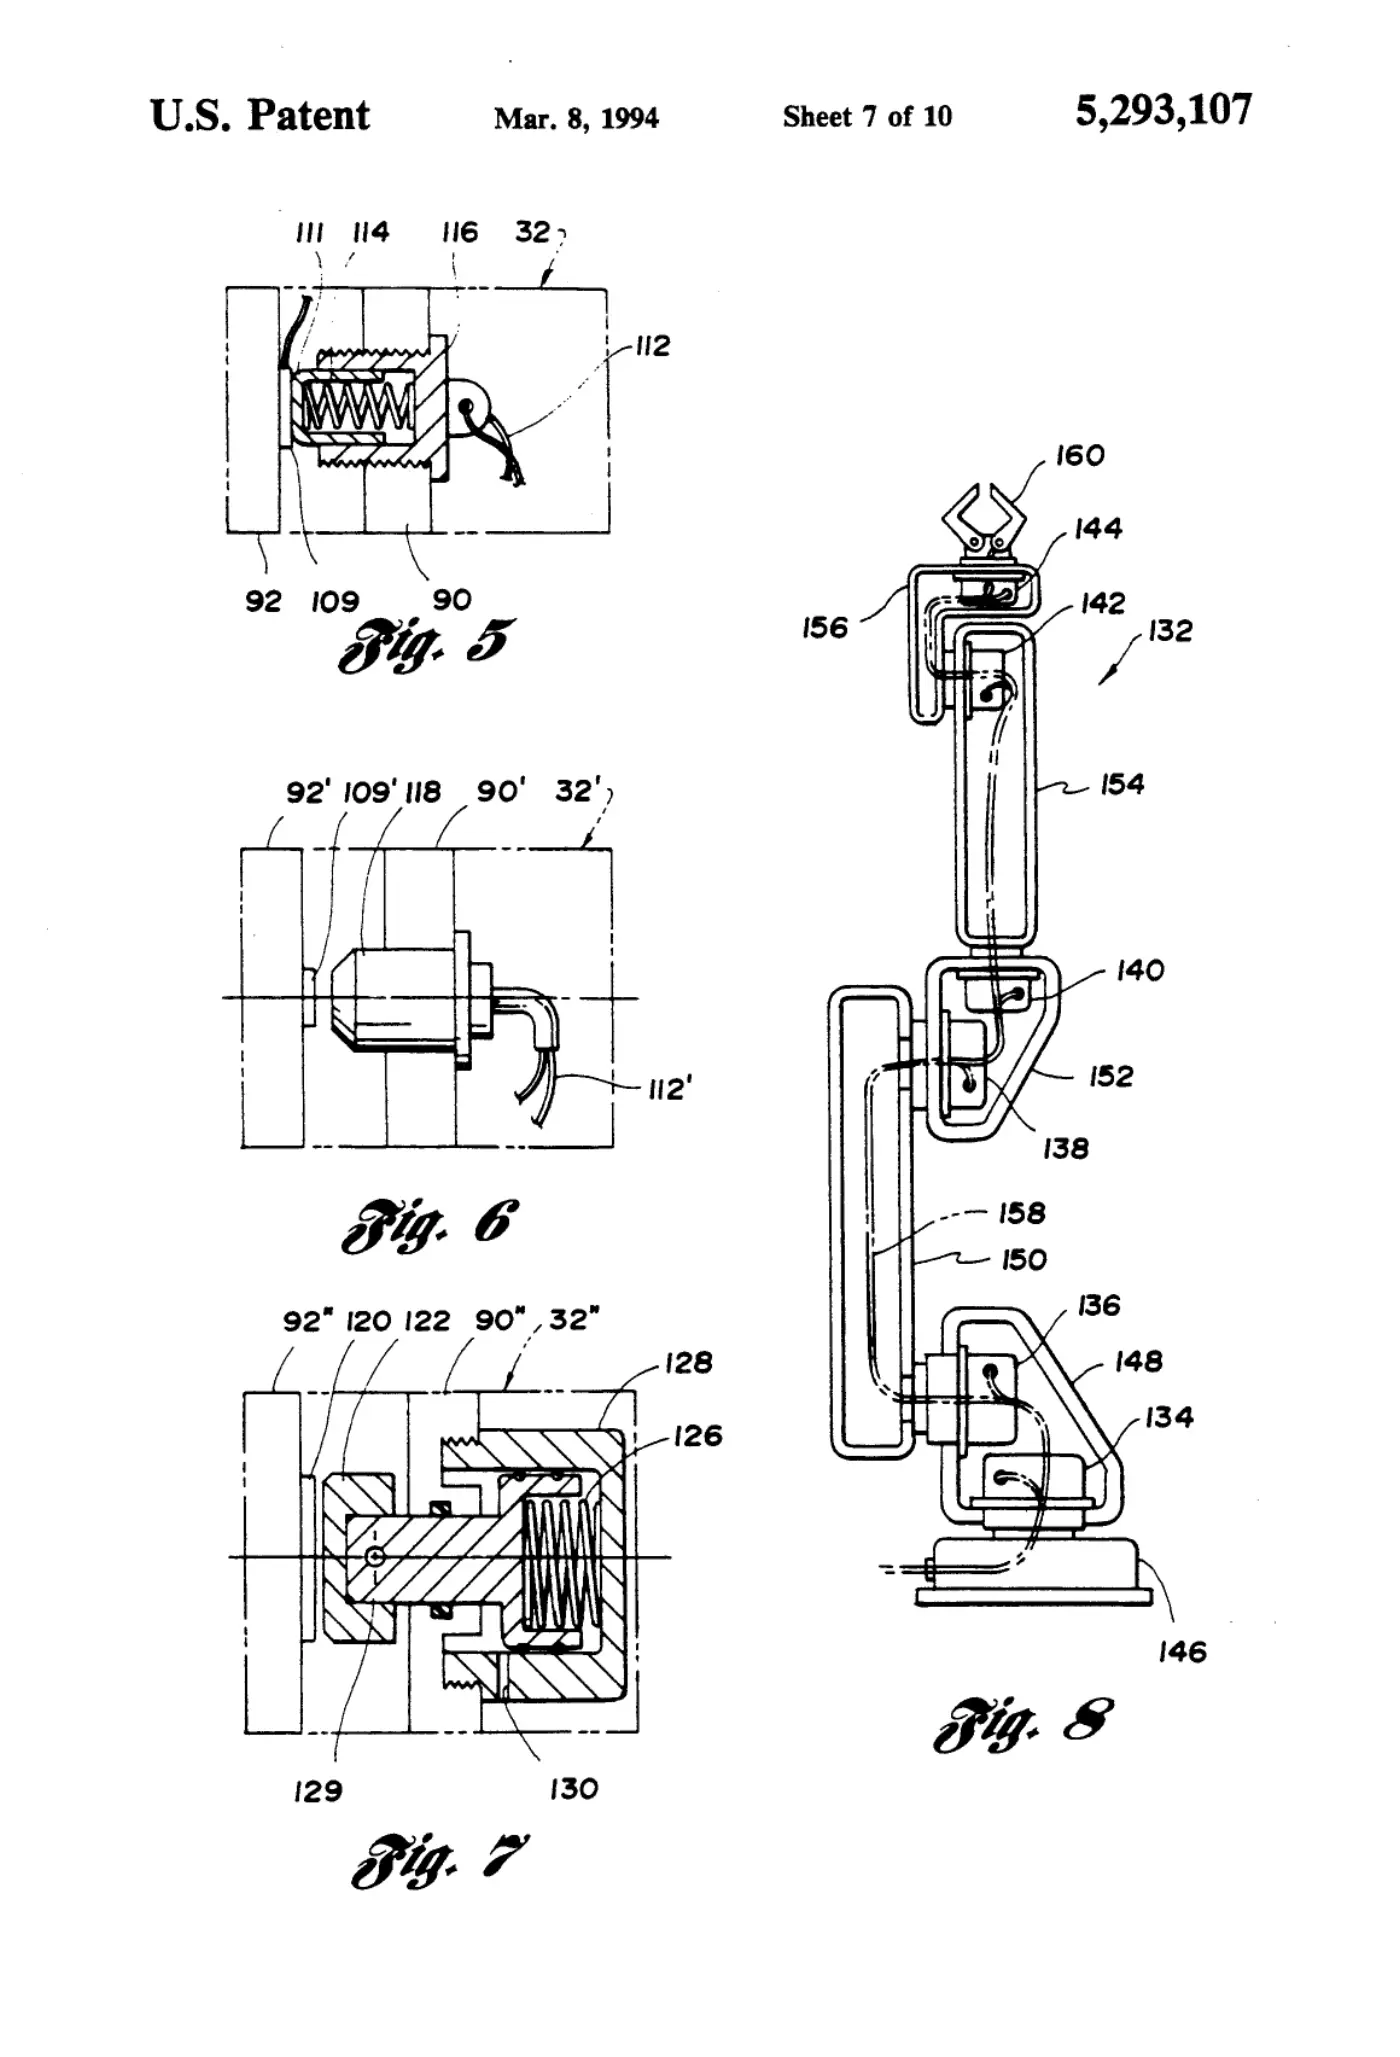
[0007]Sheet 7.
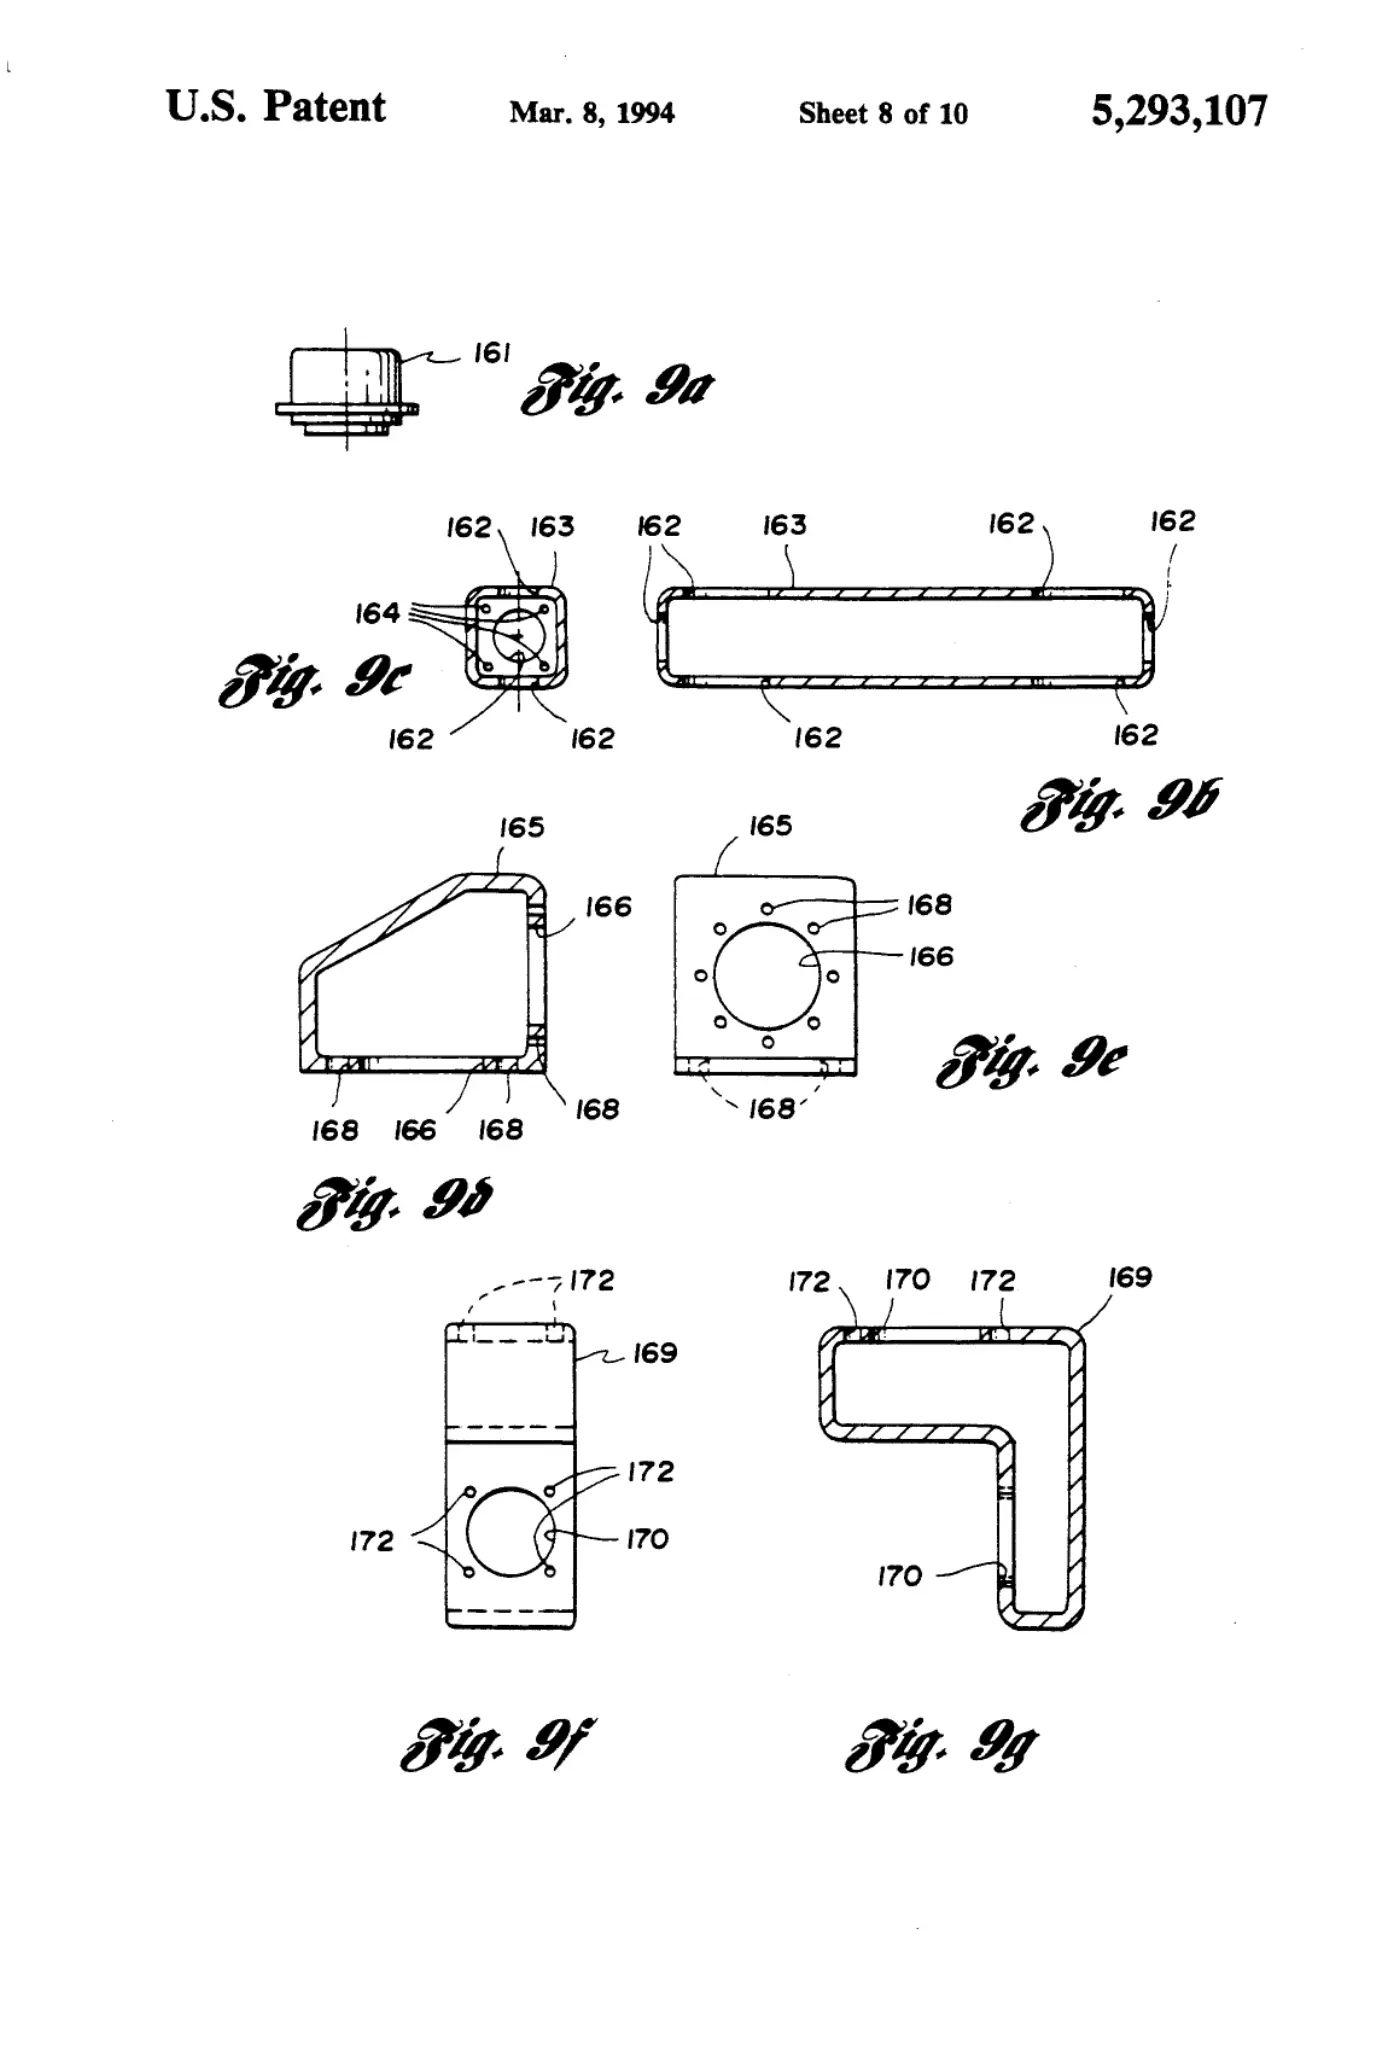
[0008]Sheet 8.
[0009]Sheet 9.
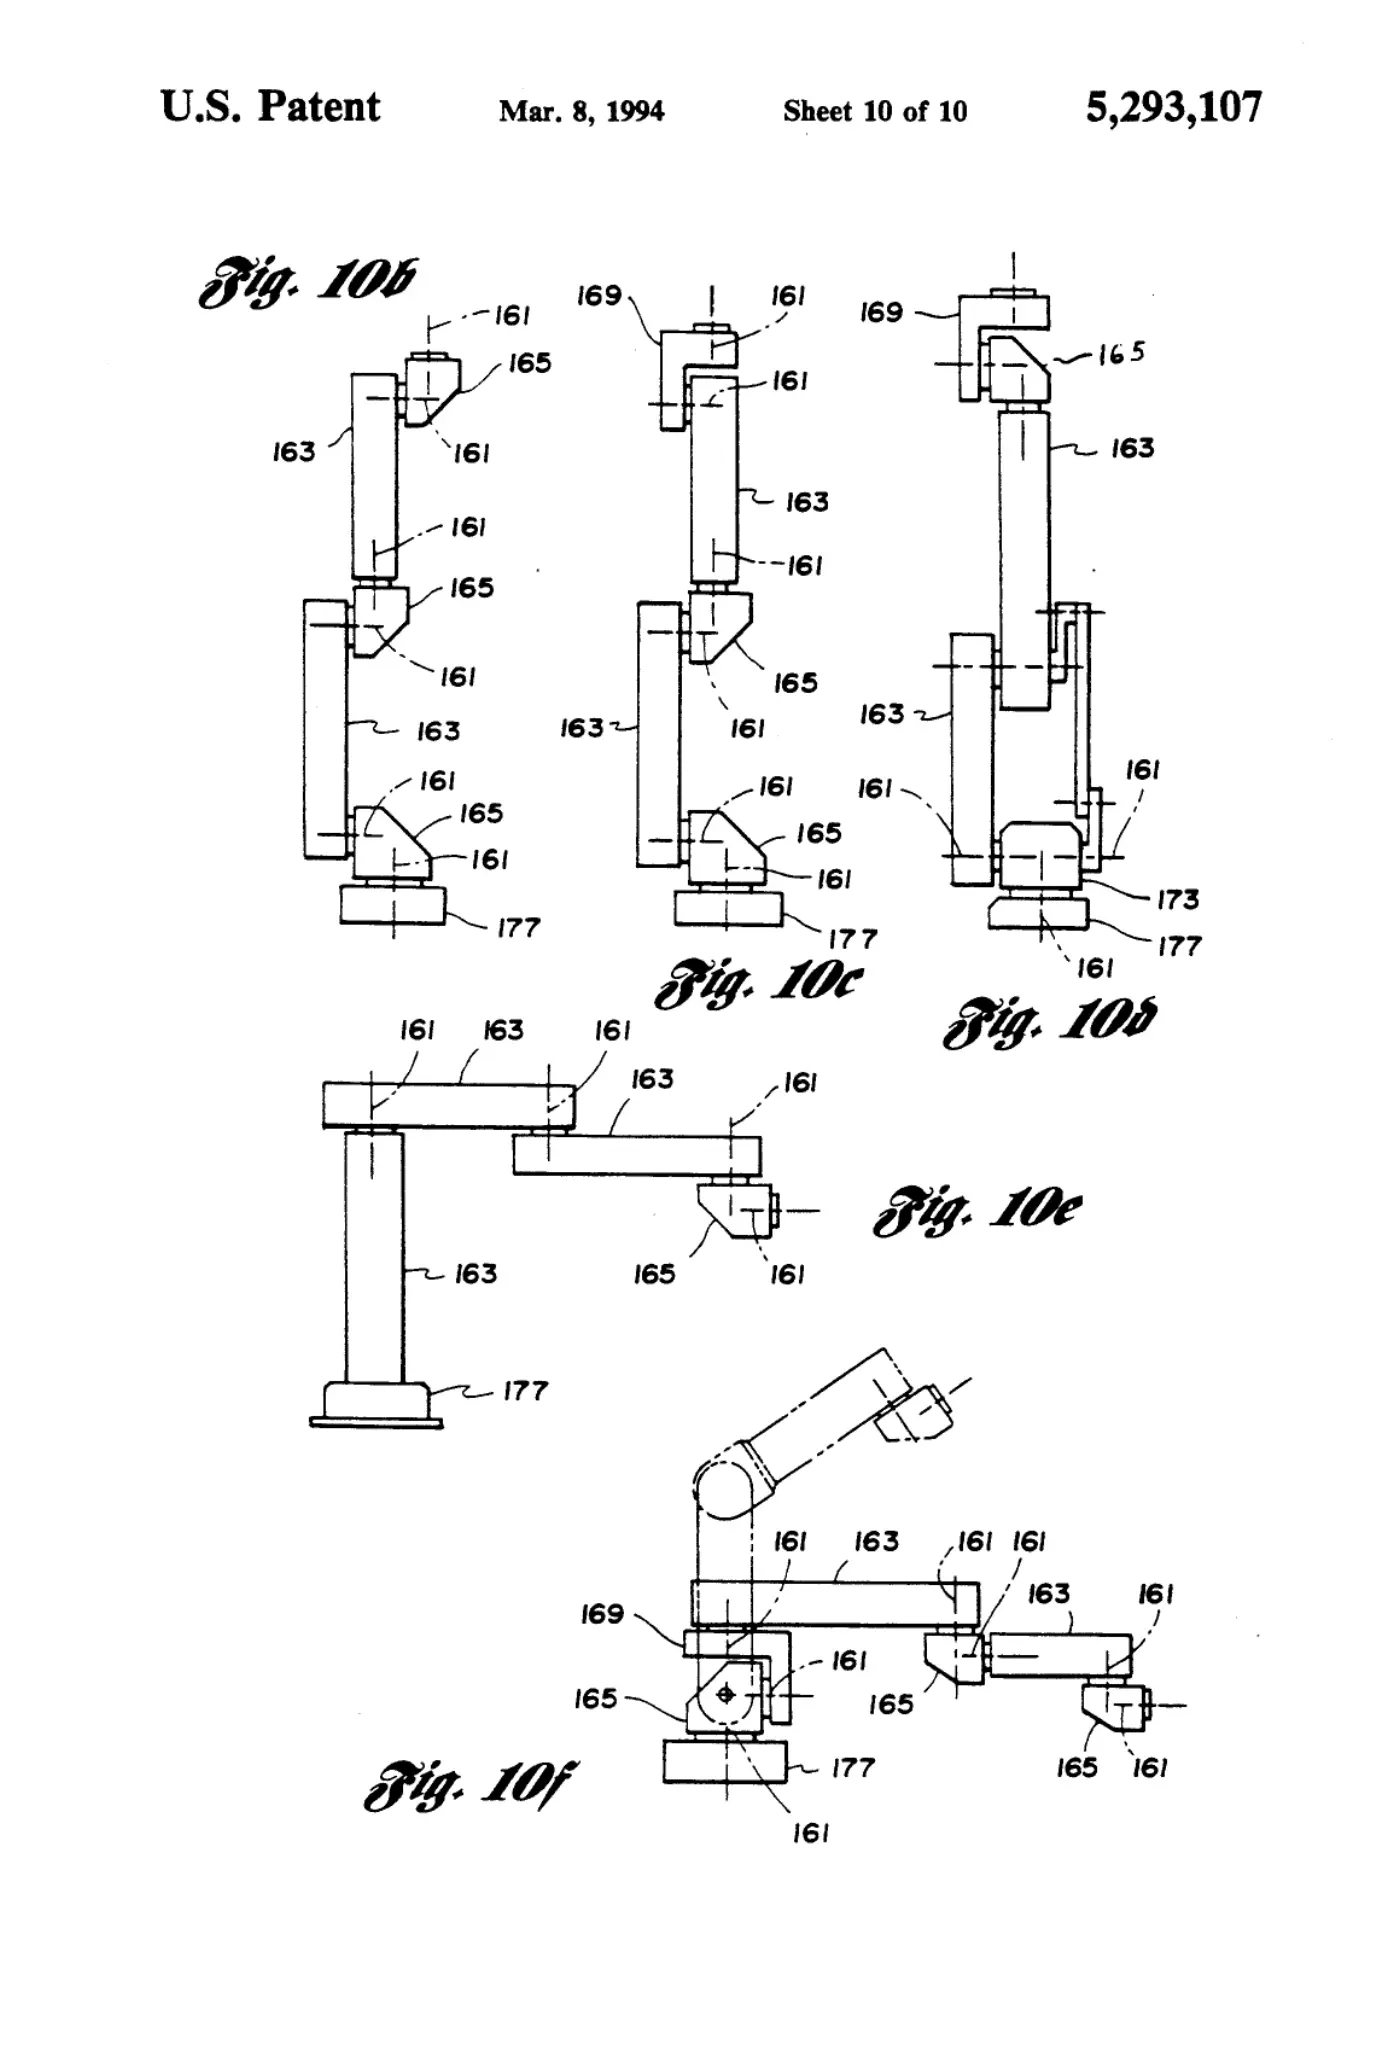
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003354, “Motorized rotary joint and method of constructing a modular robot utilizing same,” published September 15, 2026 at 20:15:08 UTC, https://opentechnical.org/p/OT-2026-000003354.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.