OT-2026-000003364
Climbing robot
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003364
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- EKLUND WAYNE D, KERLEY JAMES J, MAY EDWARD L
- Assignee
- US ARMY
- Original source
- US-5257669-A, the United States Patent and Trademark Office, 2 November 1993
- Document SHA-256
- 3566296a41a03645e0c2ed1c888d61838e8e2a8eb5918d28336523ecda71089f
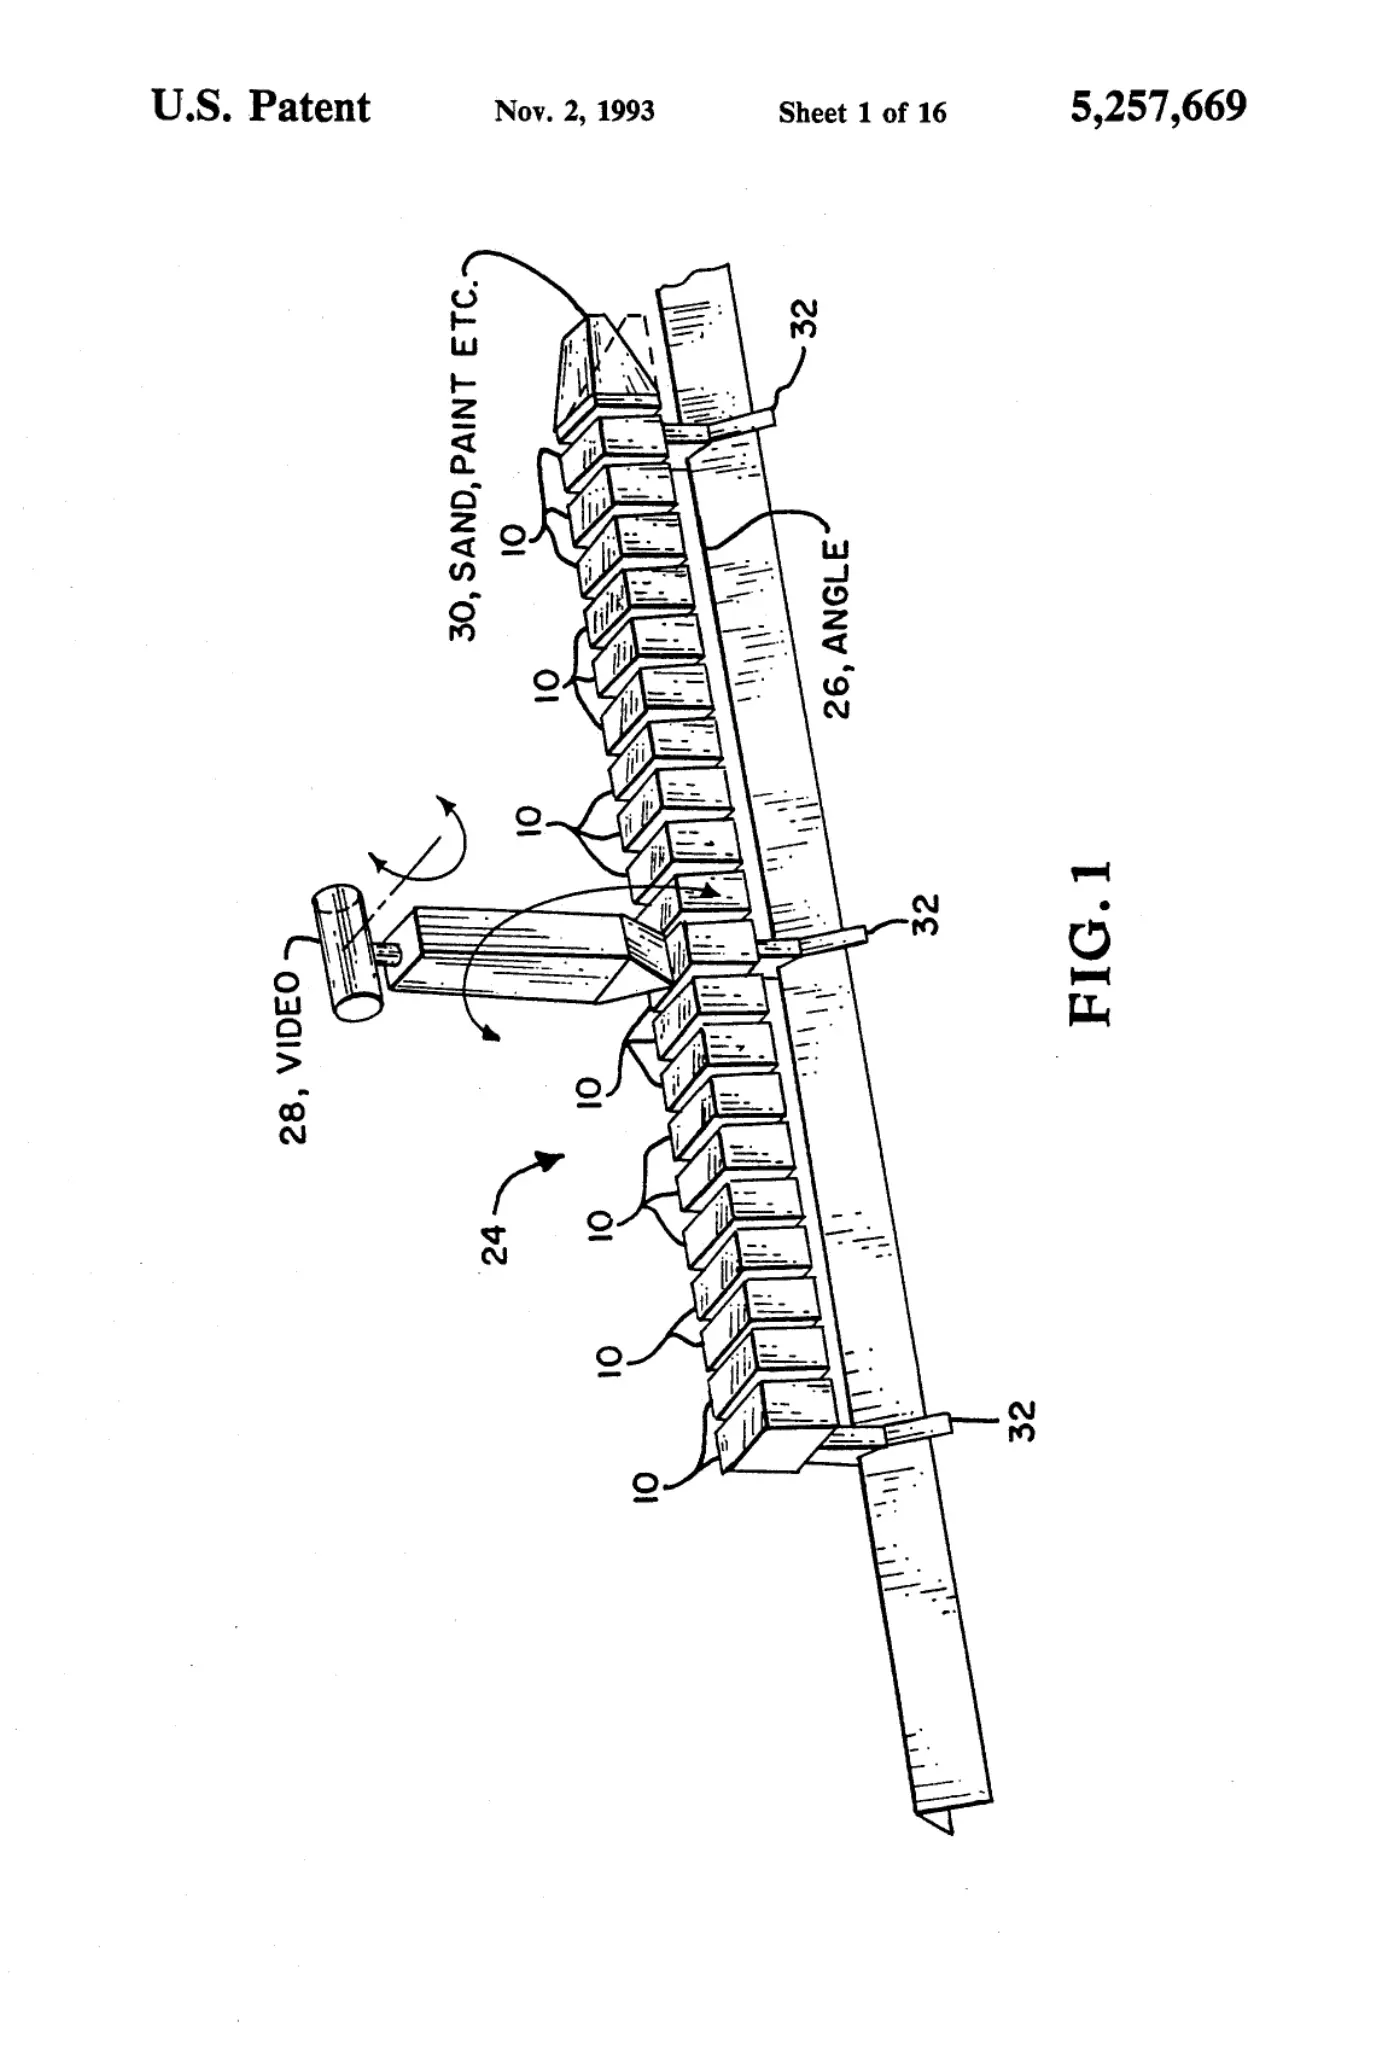
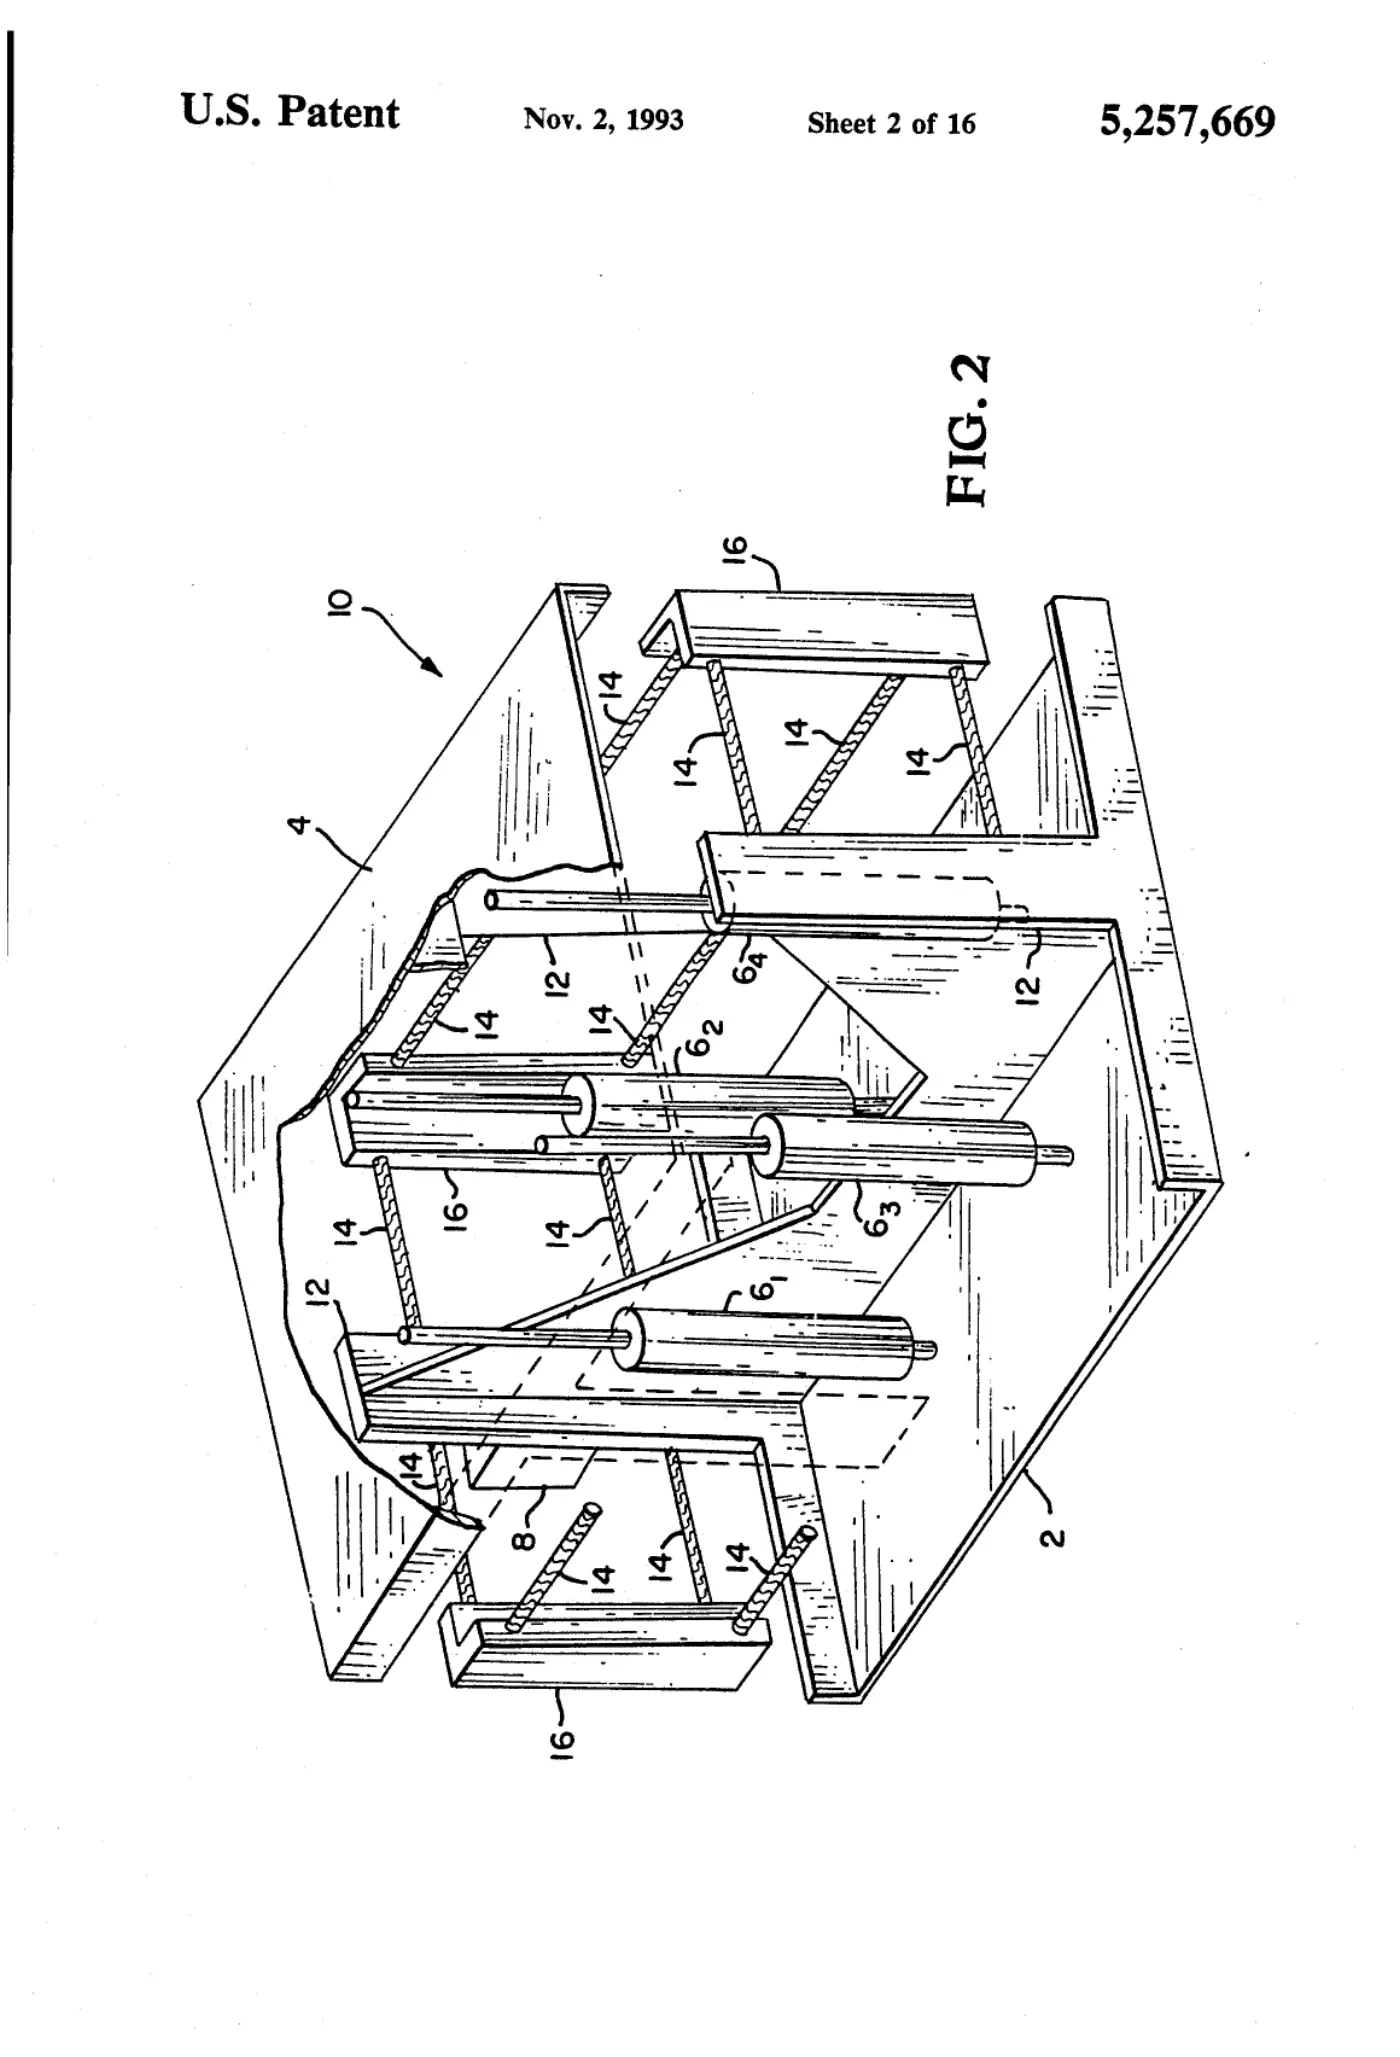
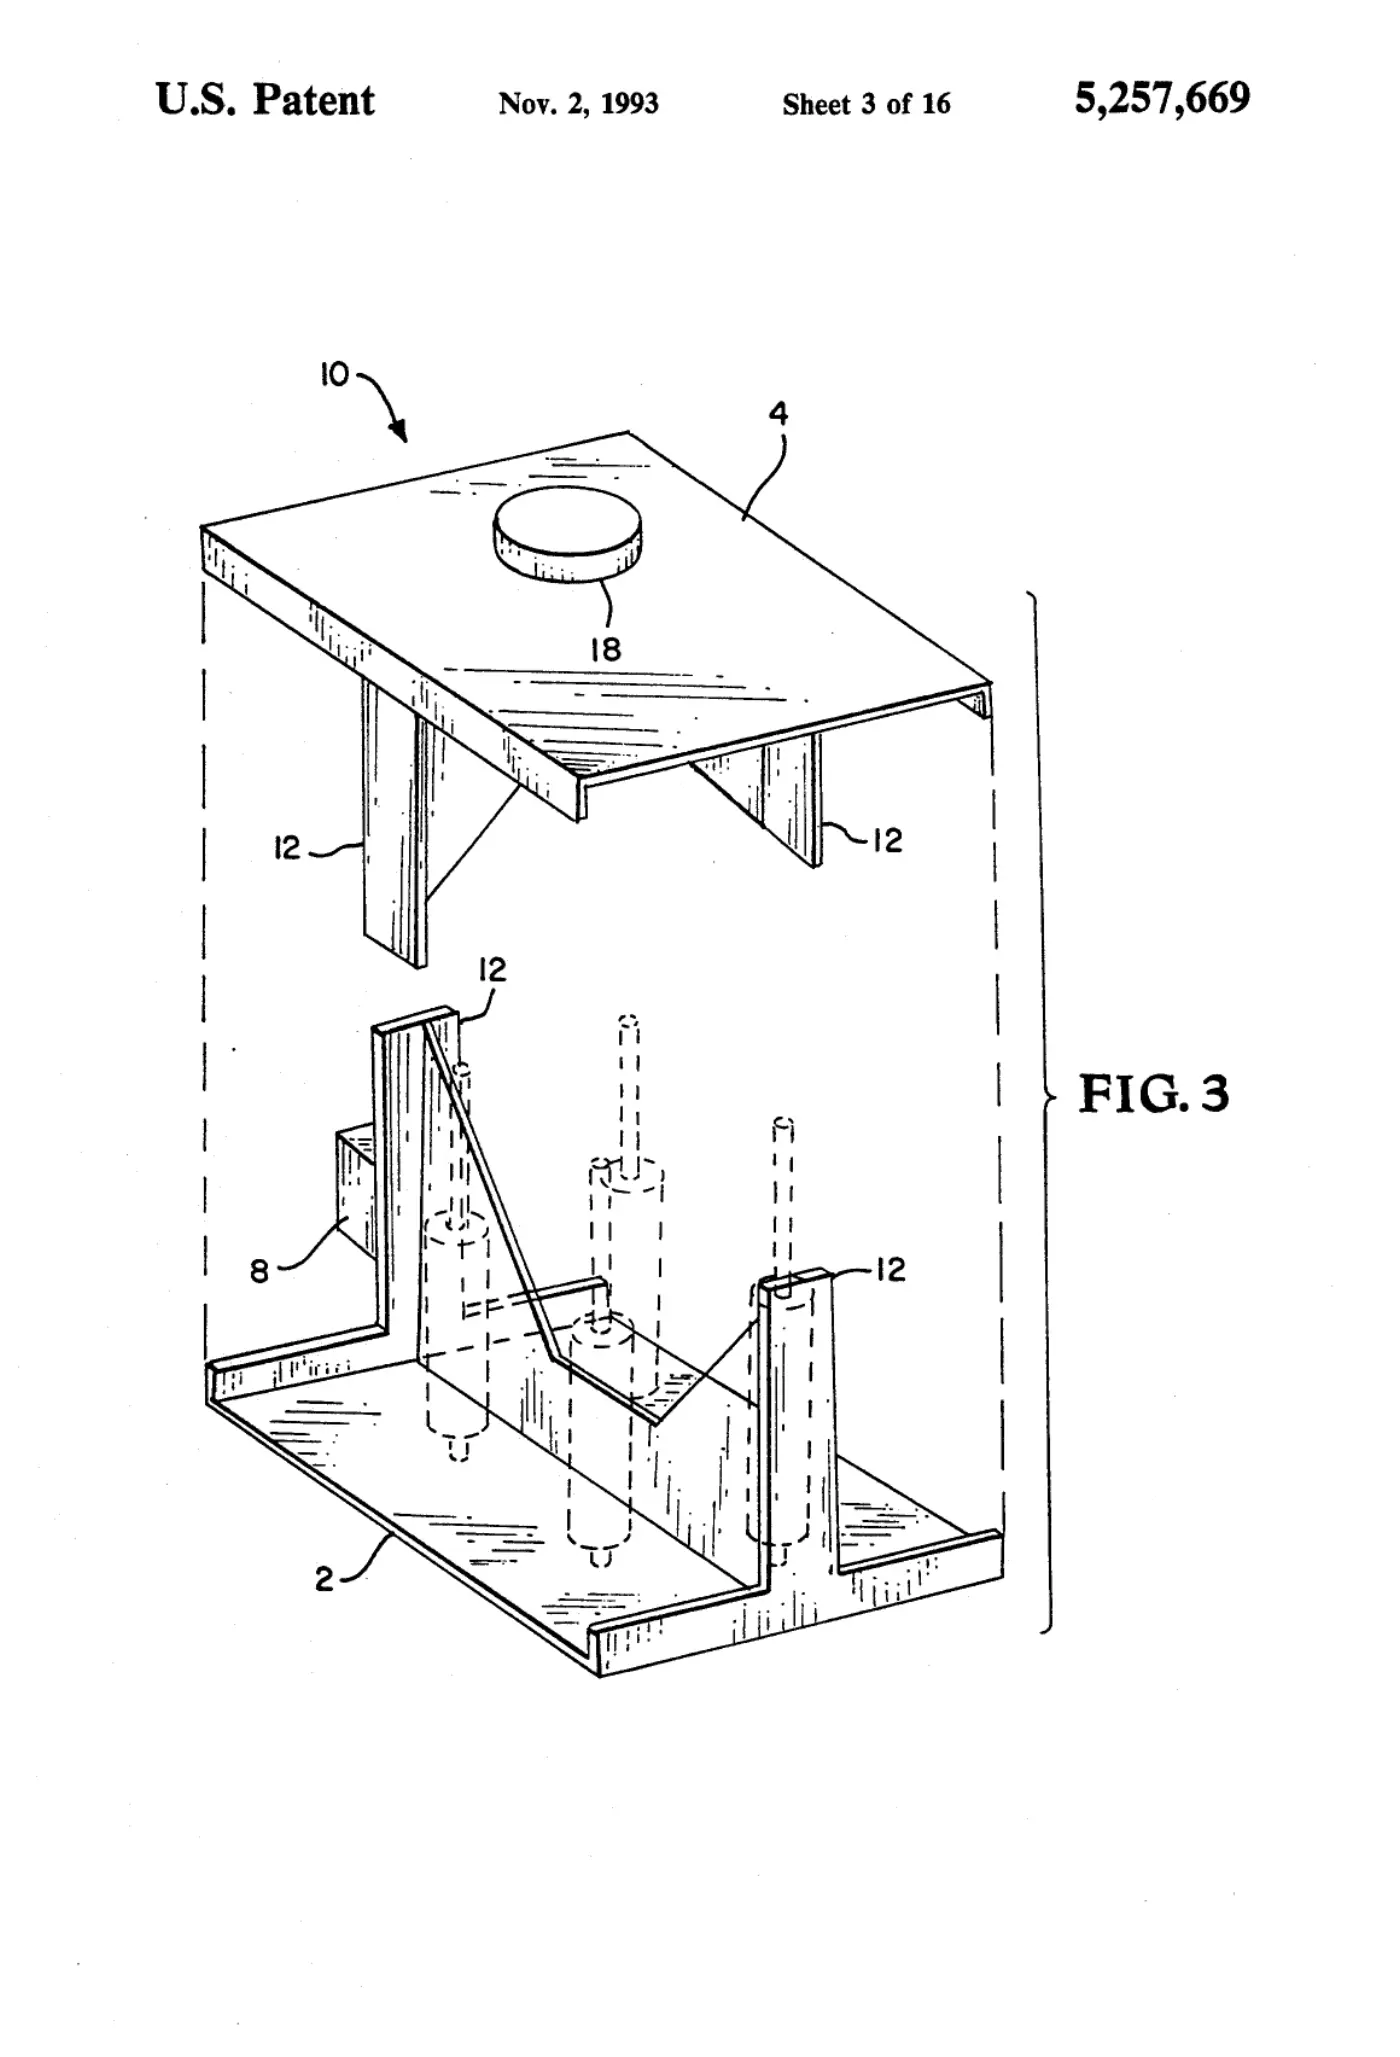
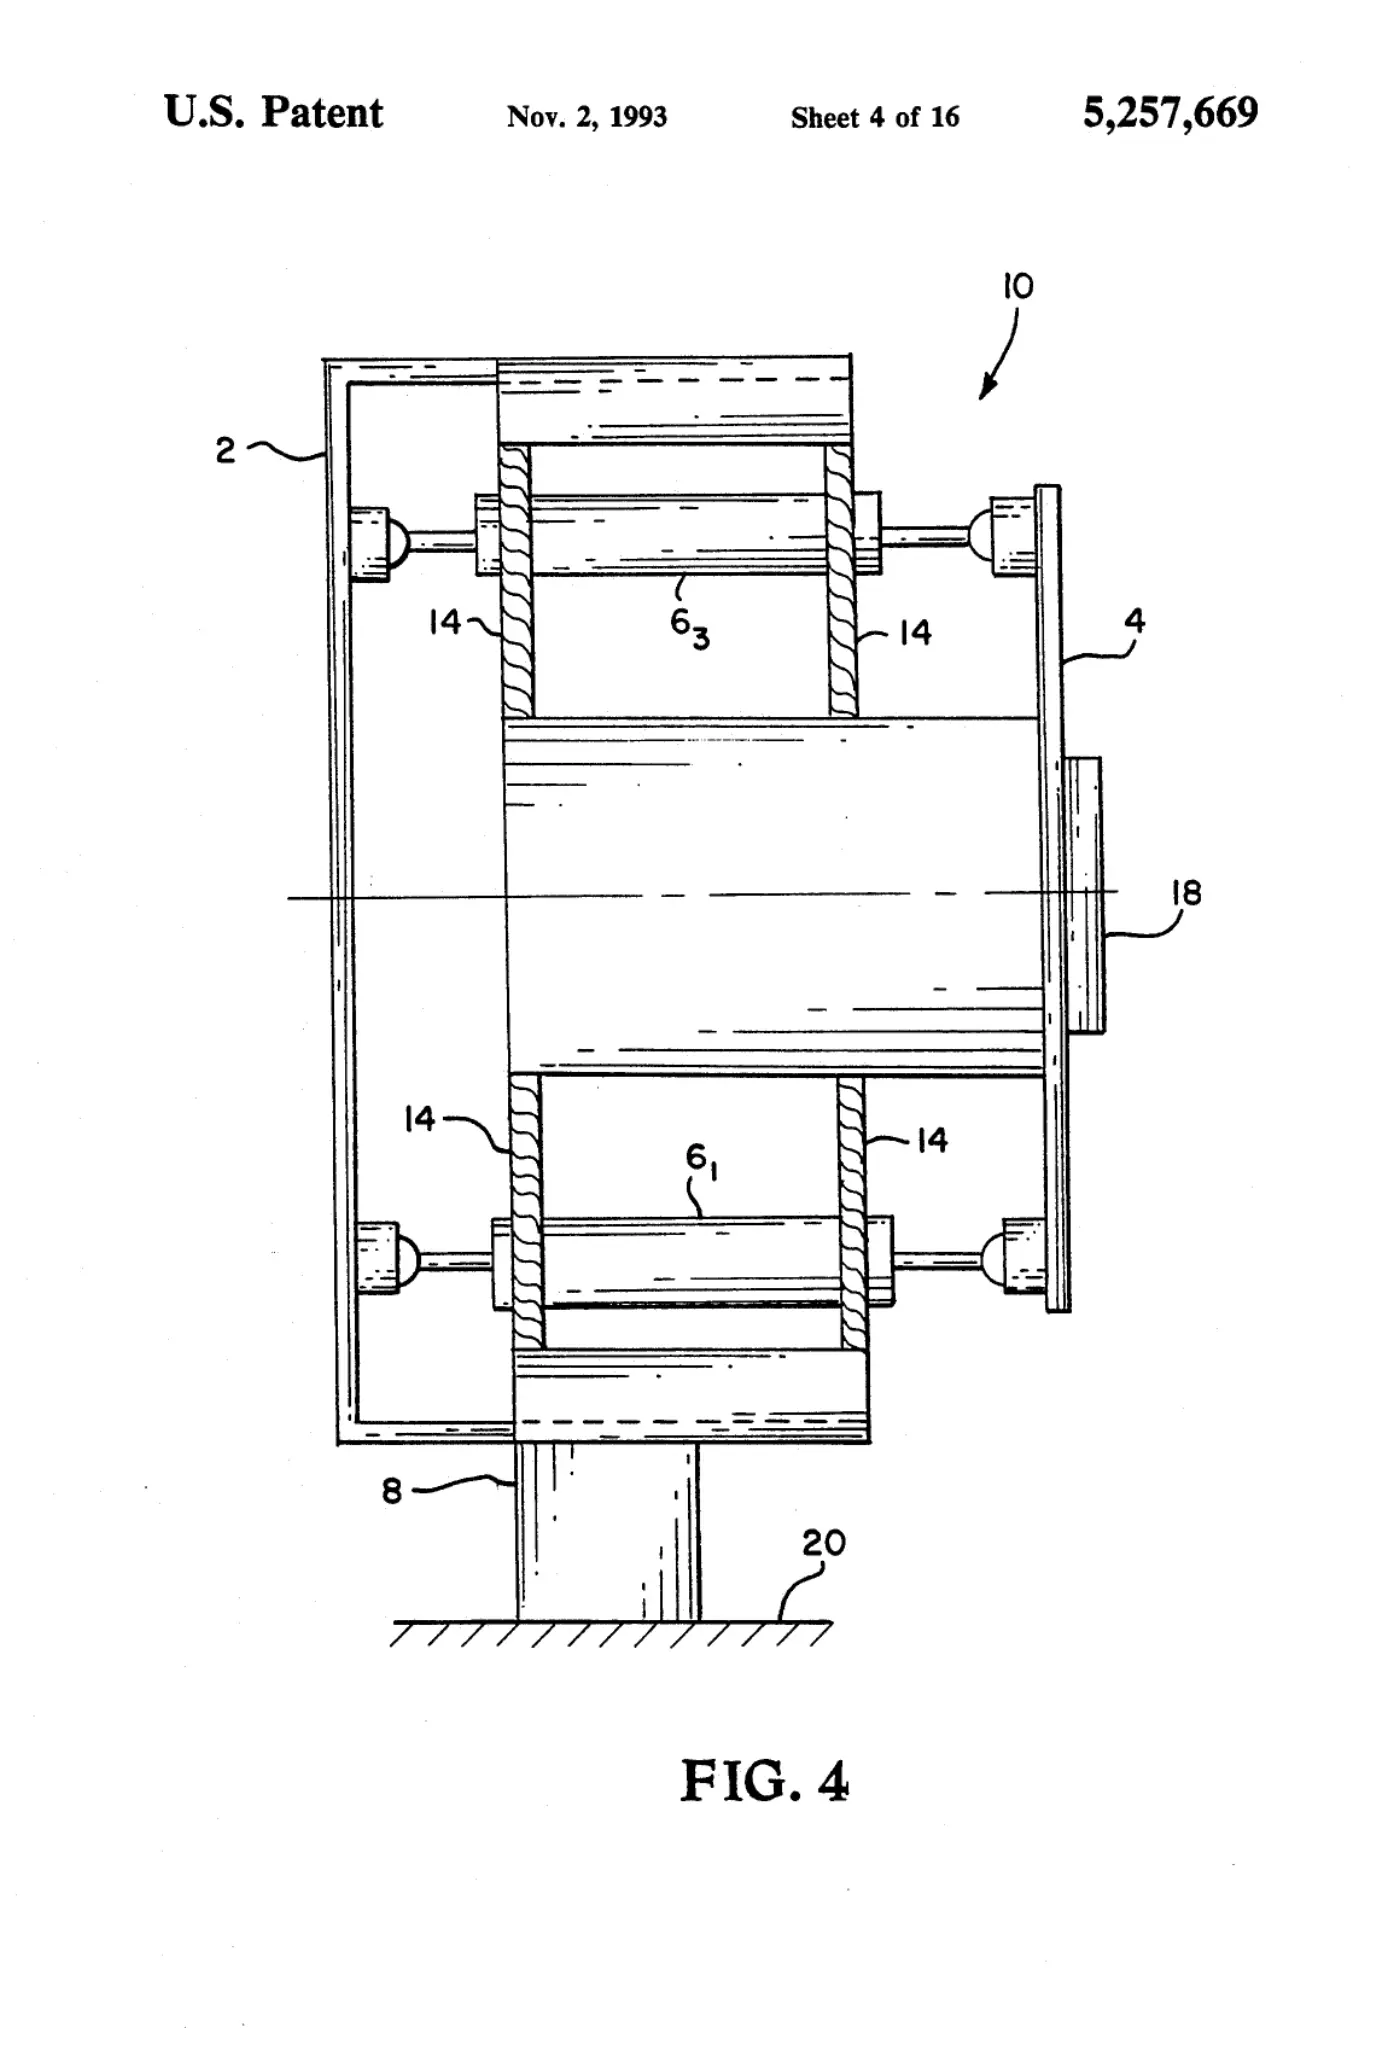
A mobile robot for traversing any surface consisting of a number of interconnected segments, each interconnected segment having a first "U" frame member, a second "U" frame member, a compliant joint between the first "U" frame member and the second "U" frame member, a number of linear actuators between the two frame members acting to provide relative displacement between the frame members, a foot attached to the second "U" frame member for adherence of the segment to the surface, an inter-segment attachment attached to the first "U" frame member for interconnecting the segments, a power source connected to the linear actuators, and a computer/controller for independently controlling each linear actuator in each interconnected segment such that the mobile robot moves in a caterpillar like fashion.
Abstract
A mobile robot for traversing any surface consisting of a number of interconnected segments, each interconnected segment having a first "U" frame member, a second "U" frame member, a compliant joint between the first "U" frame member and the second "U" frame member, a number of linear actuators between the two frame members acting to provide relative displacement between the frame members, a foot attached to the second "U" frame member for adherence of the segment to the surface, an inter-segment attachment attached to the first "U" frame member for interconnecting the segments, a power source connected to the linear actuators, and a computer/controller for independently controlling each linear actuator in each interconnected segment such that the mobile robot moves in a caterpillar like fashion.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
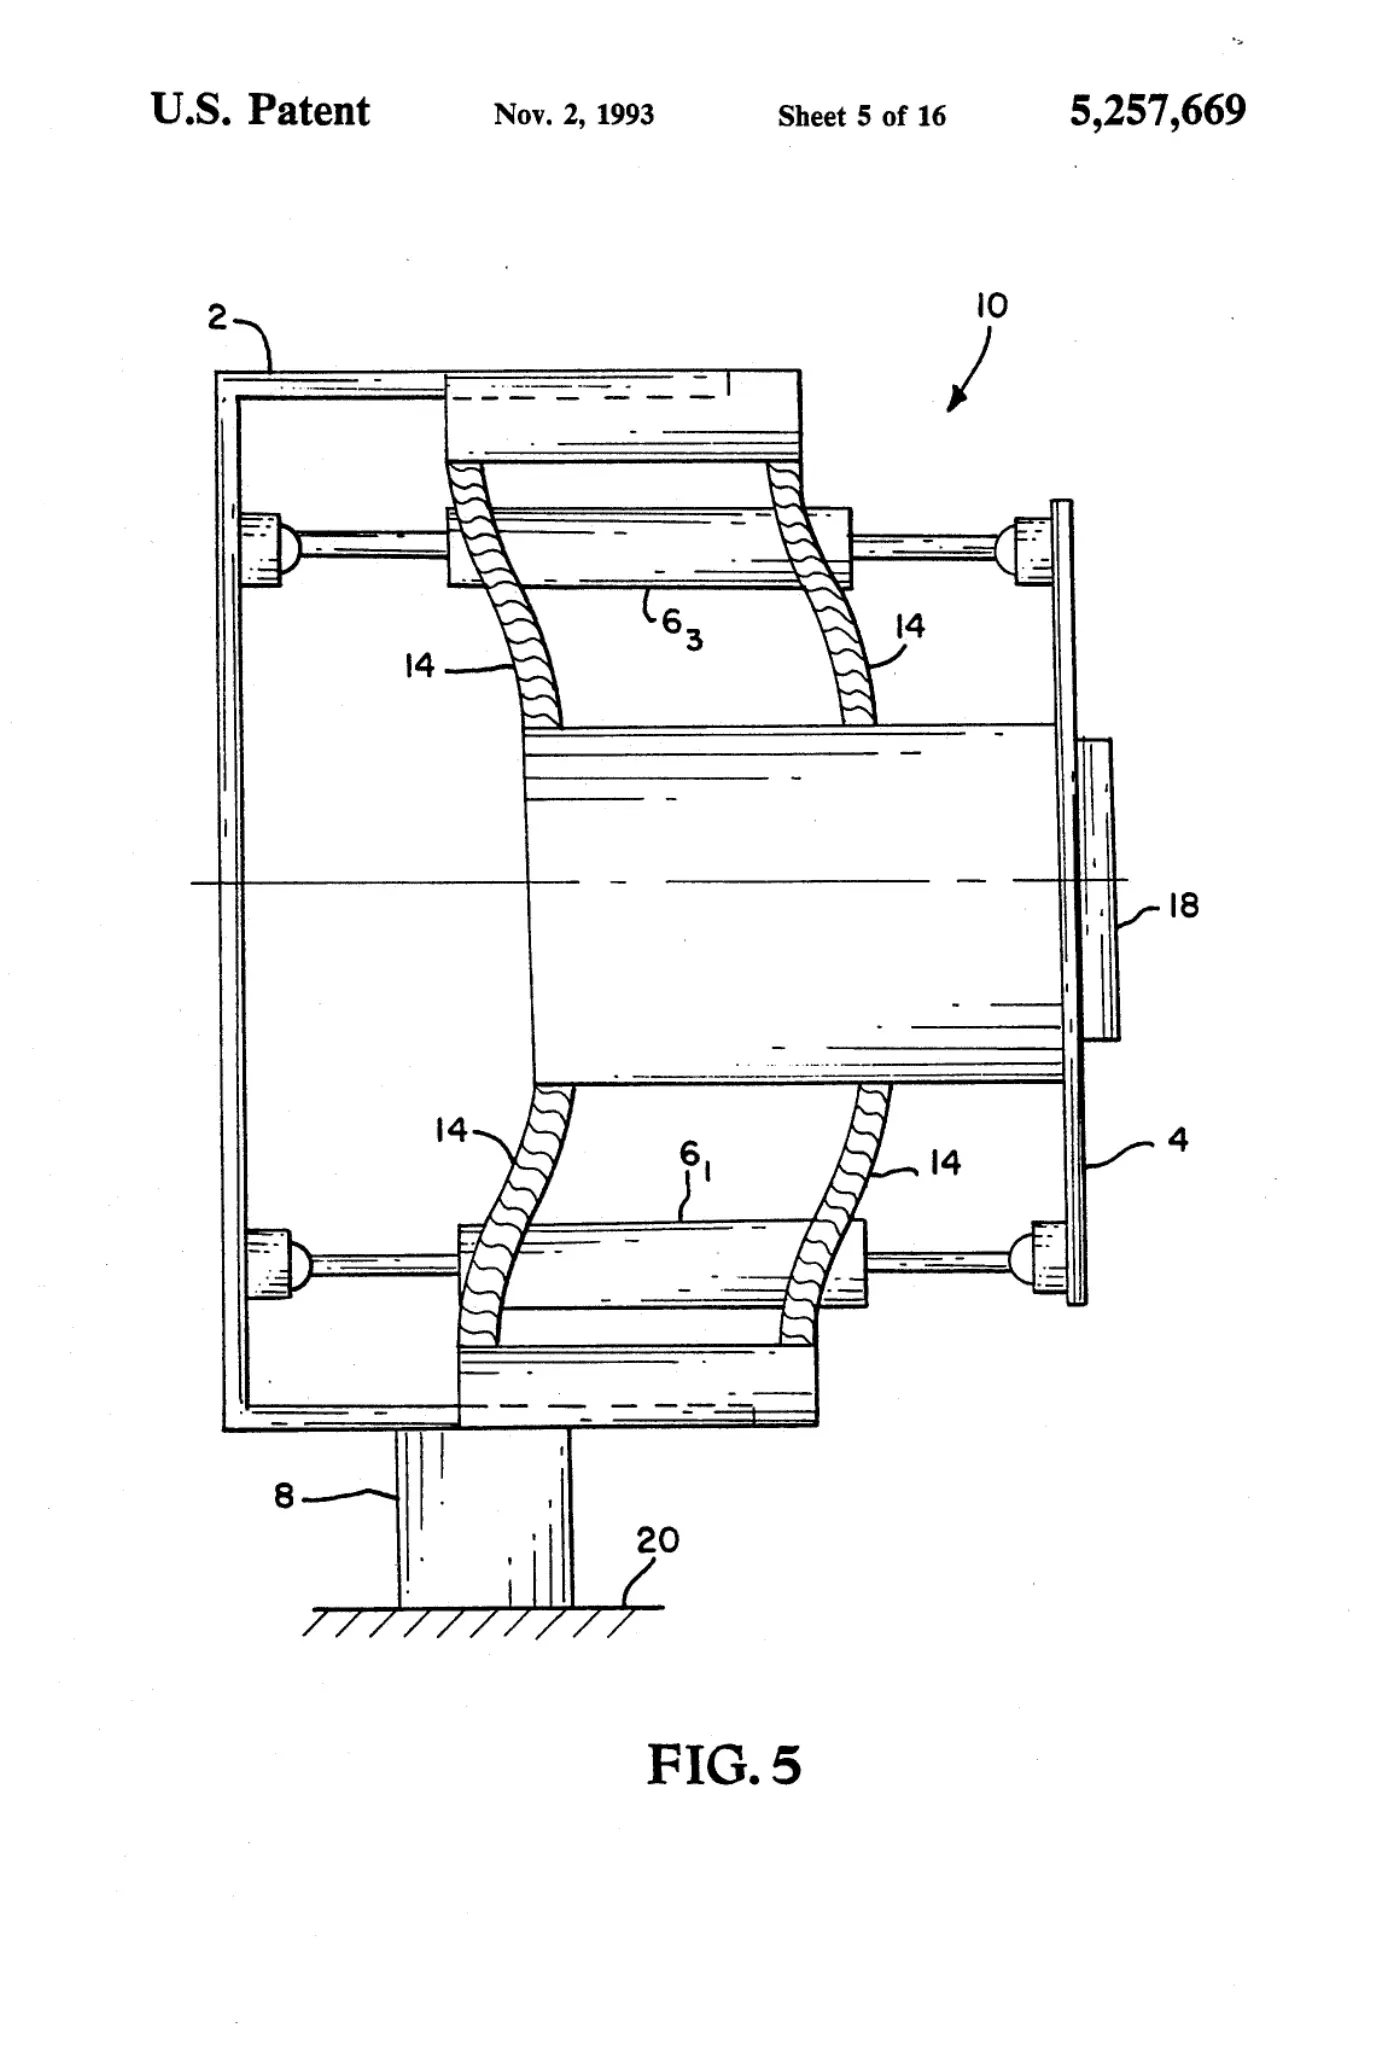
[0005]Sheet 5.
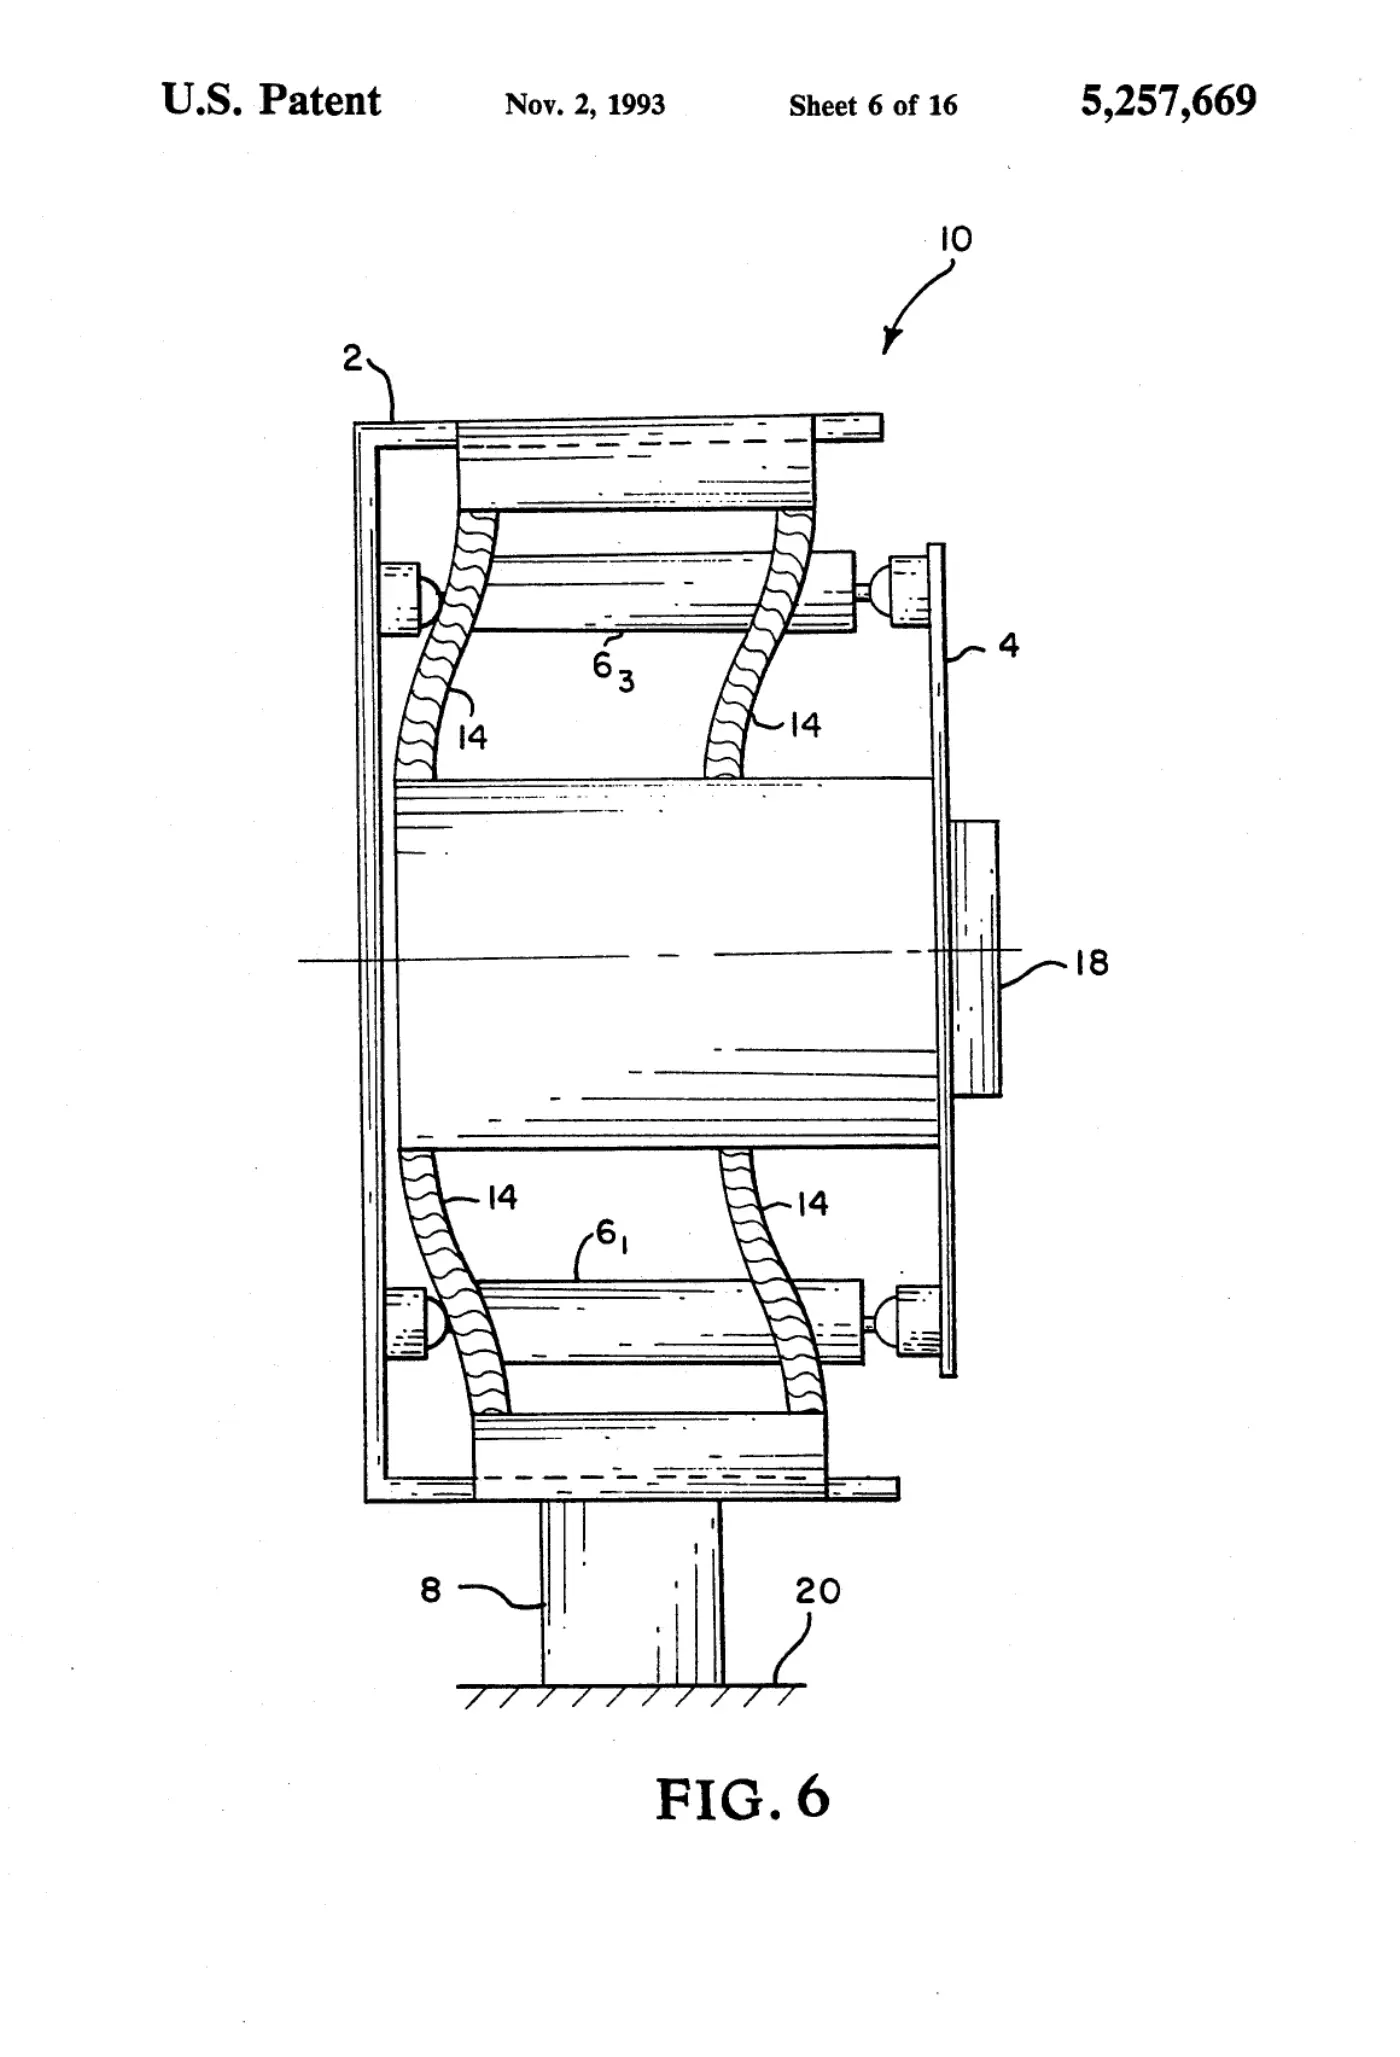
[0006]Sheet 6.
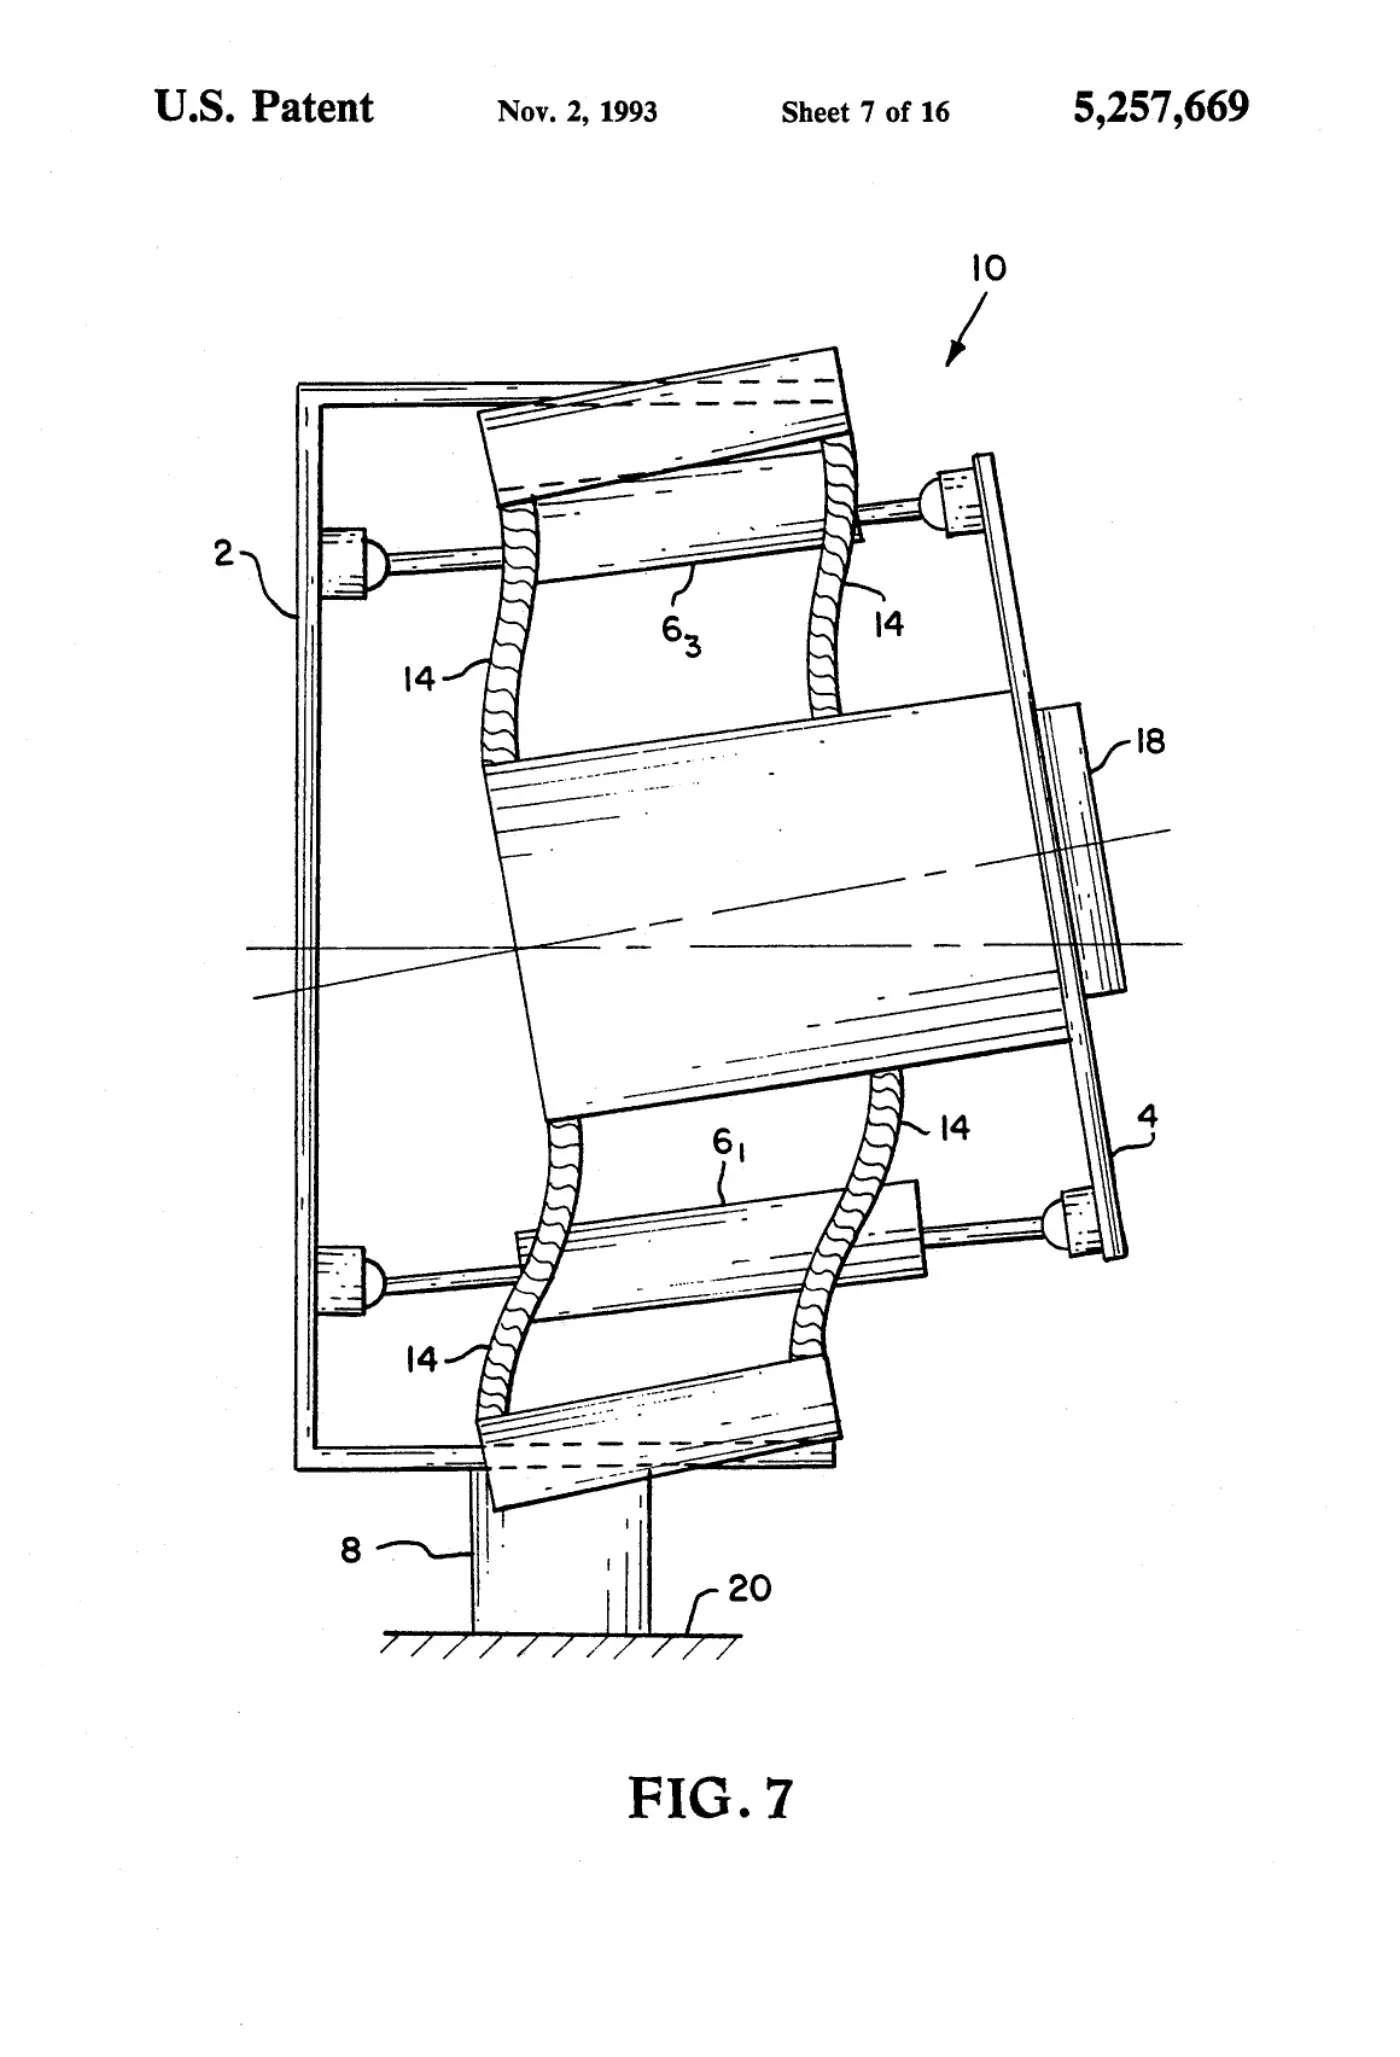
[0007]Sheet 7.
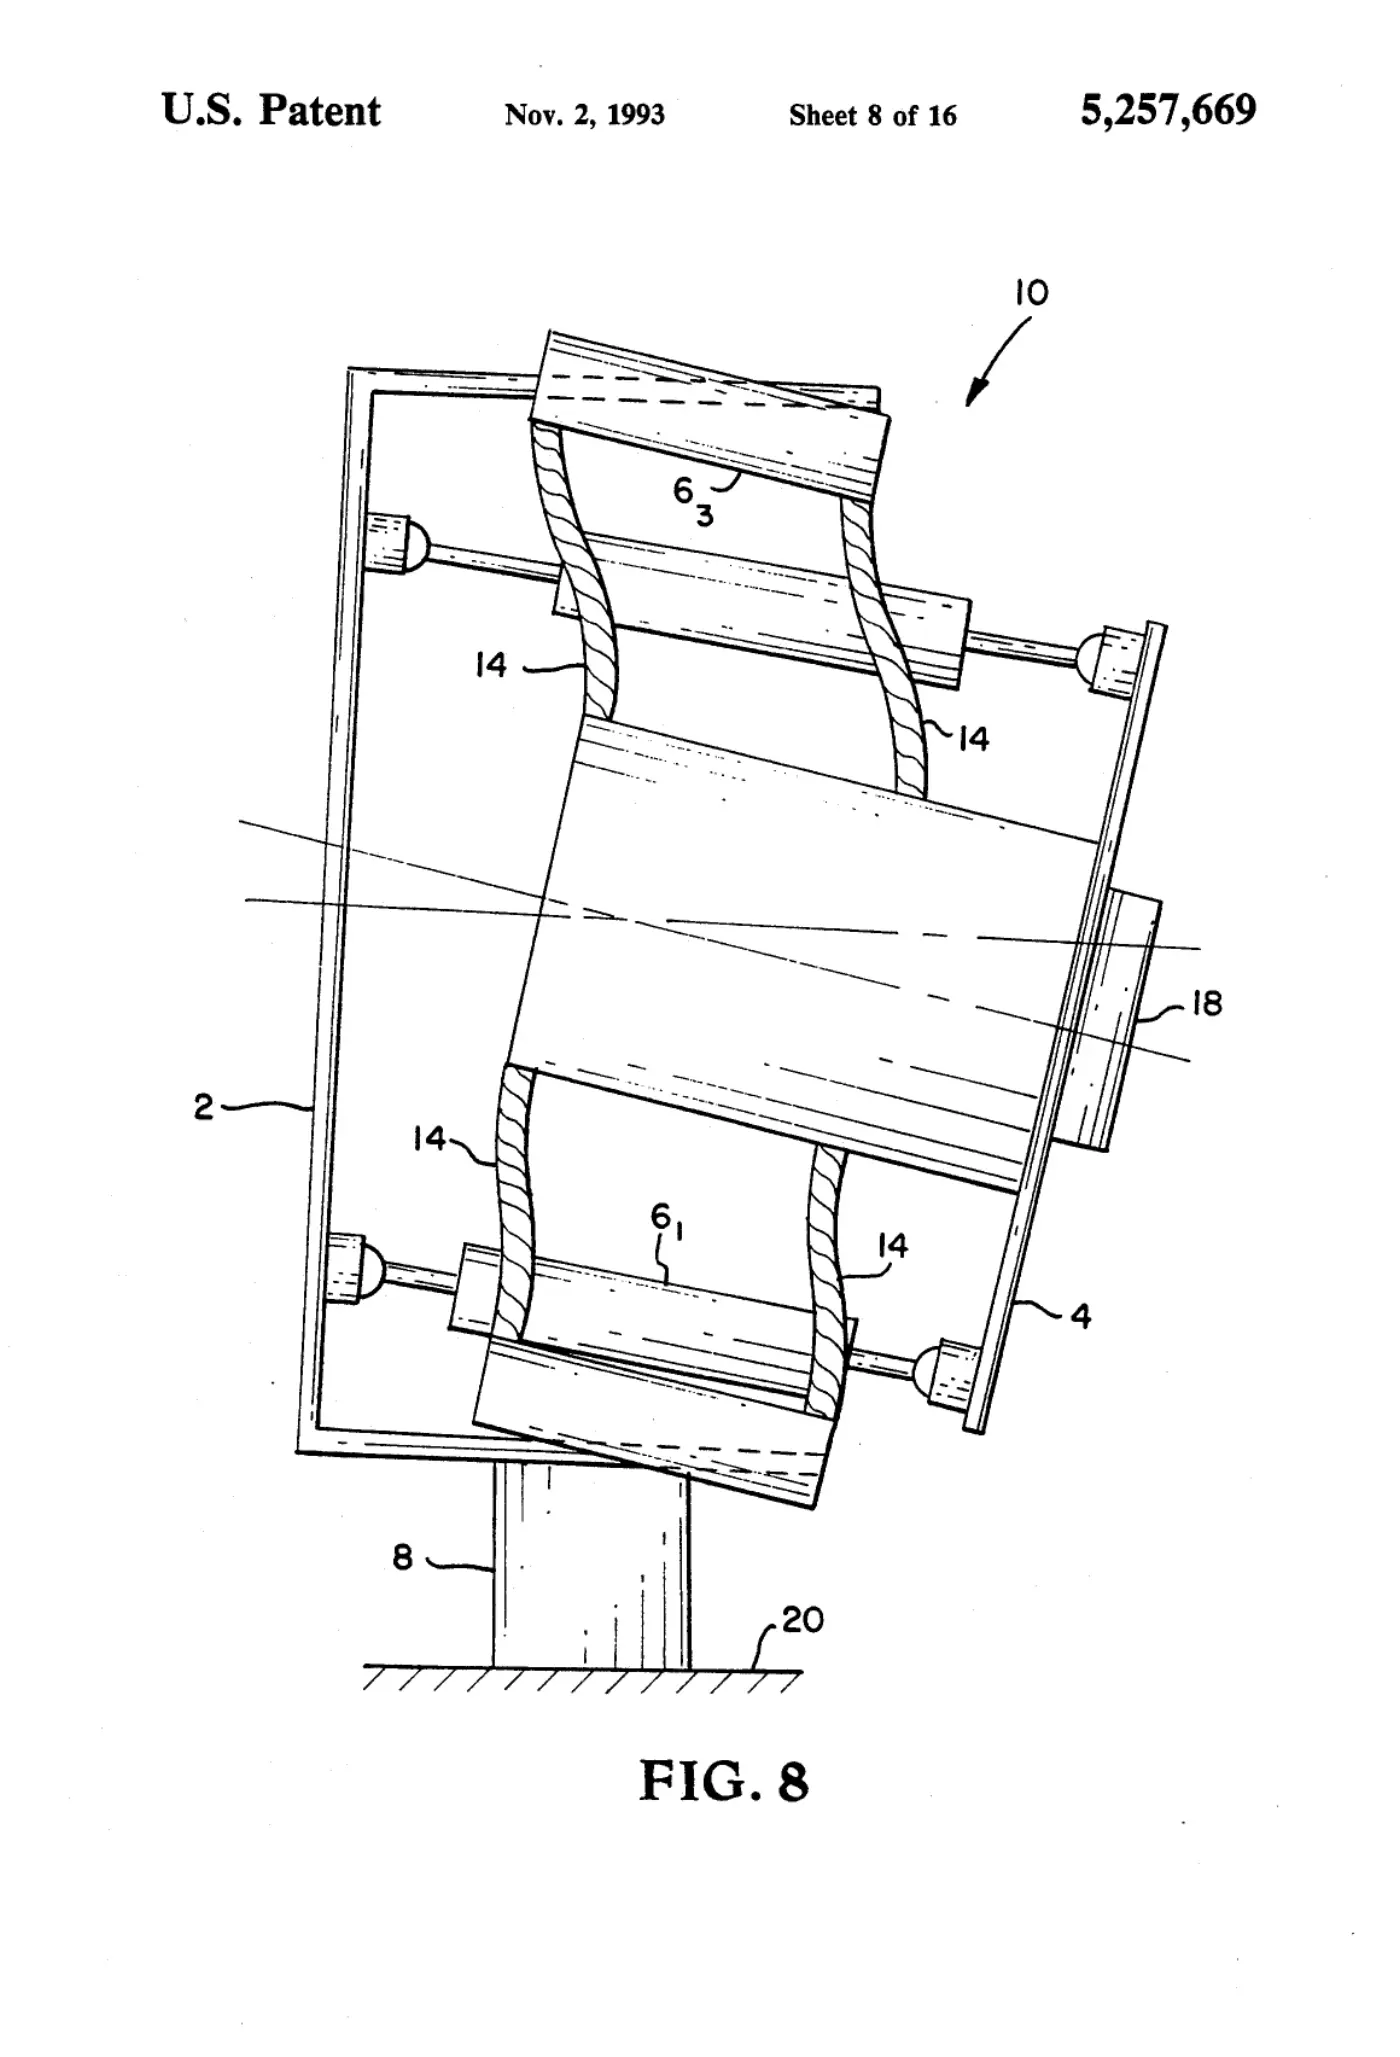
[0008]Sheet 8.
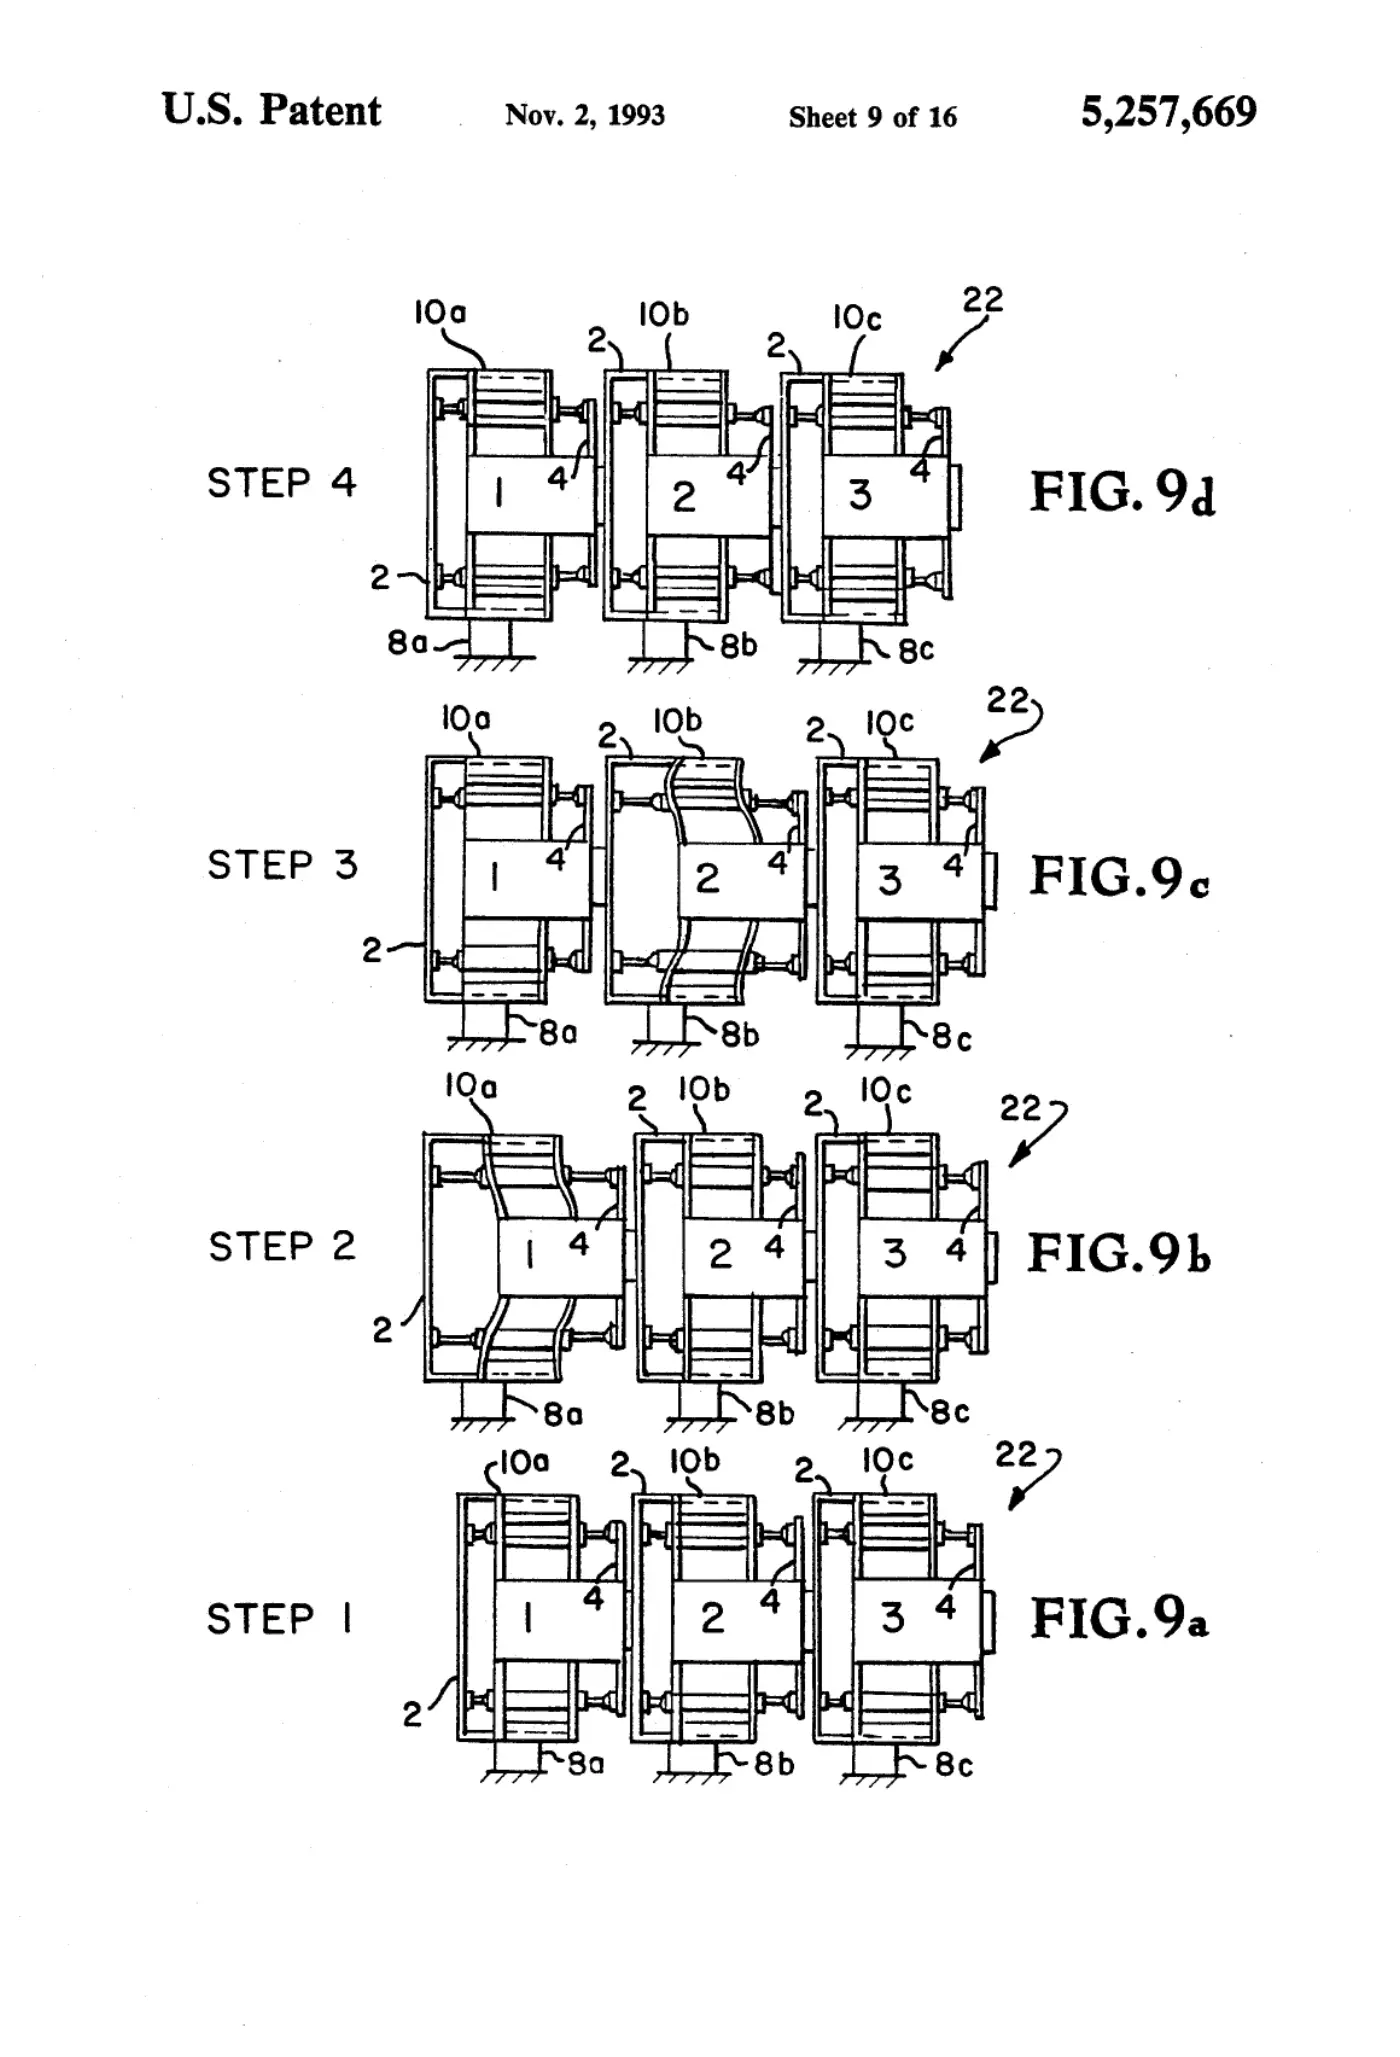
[0009]Sheet 9.
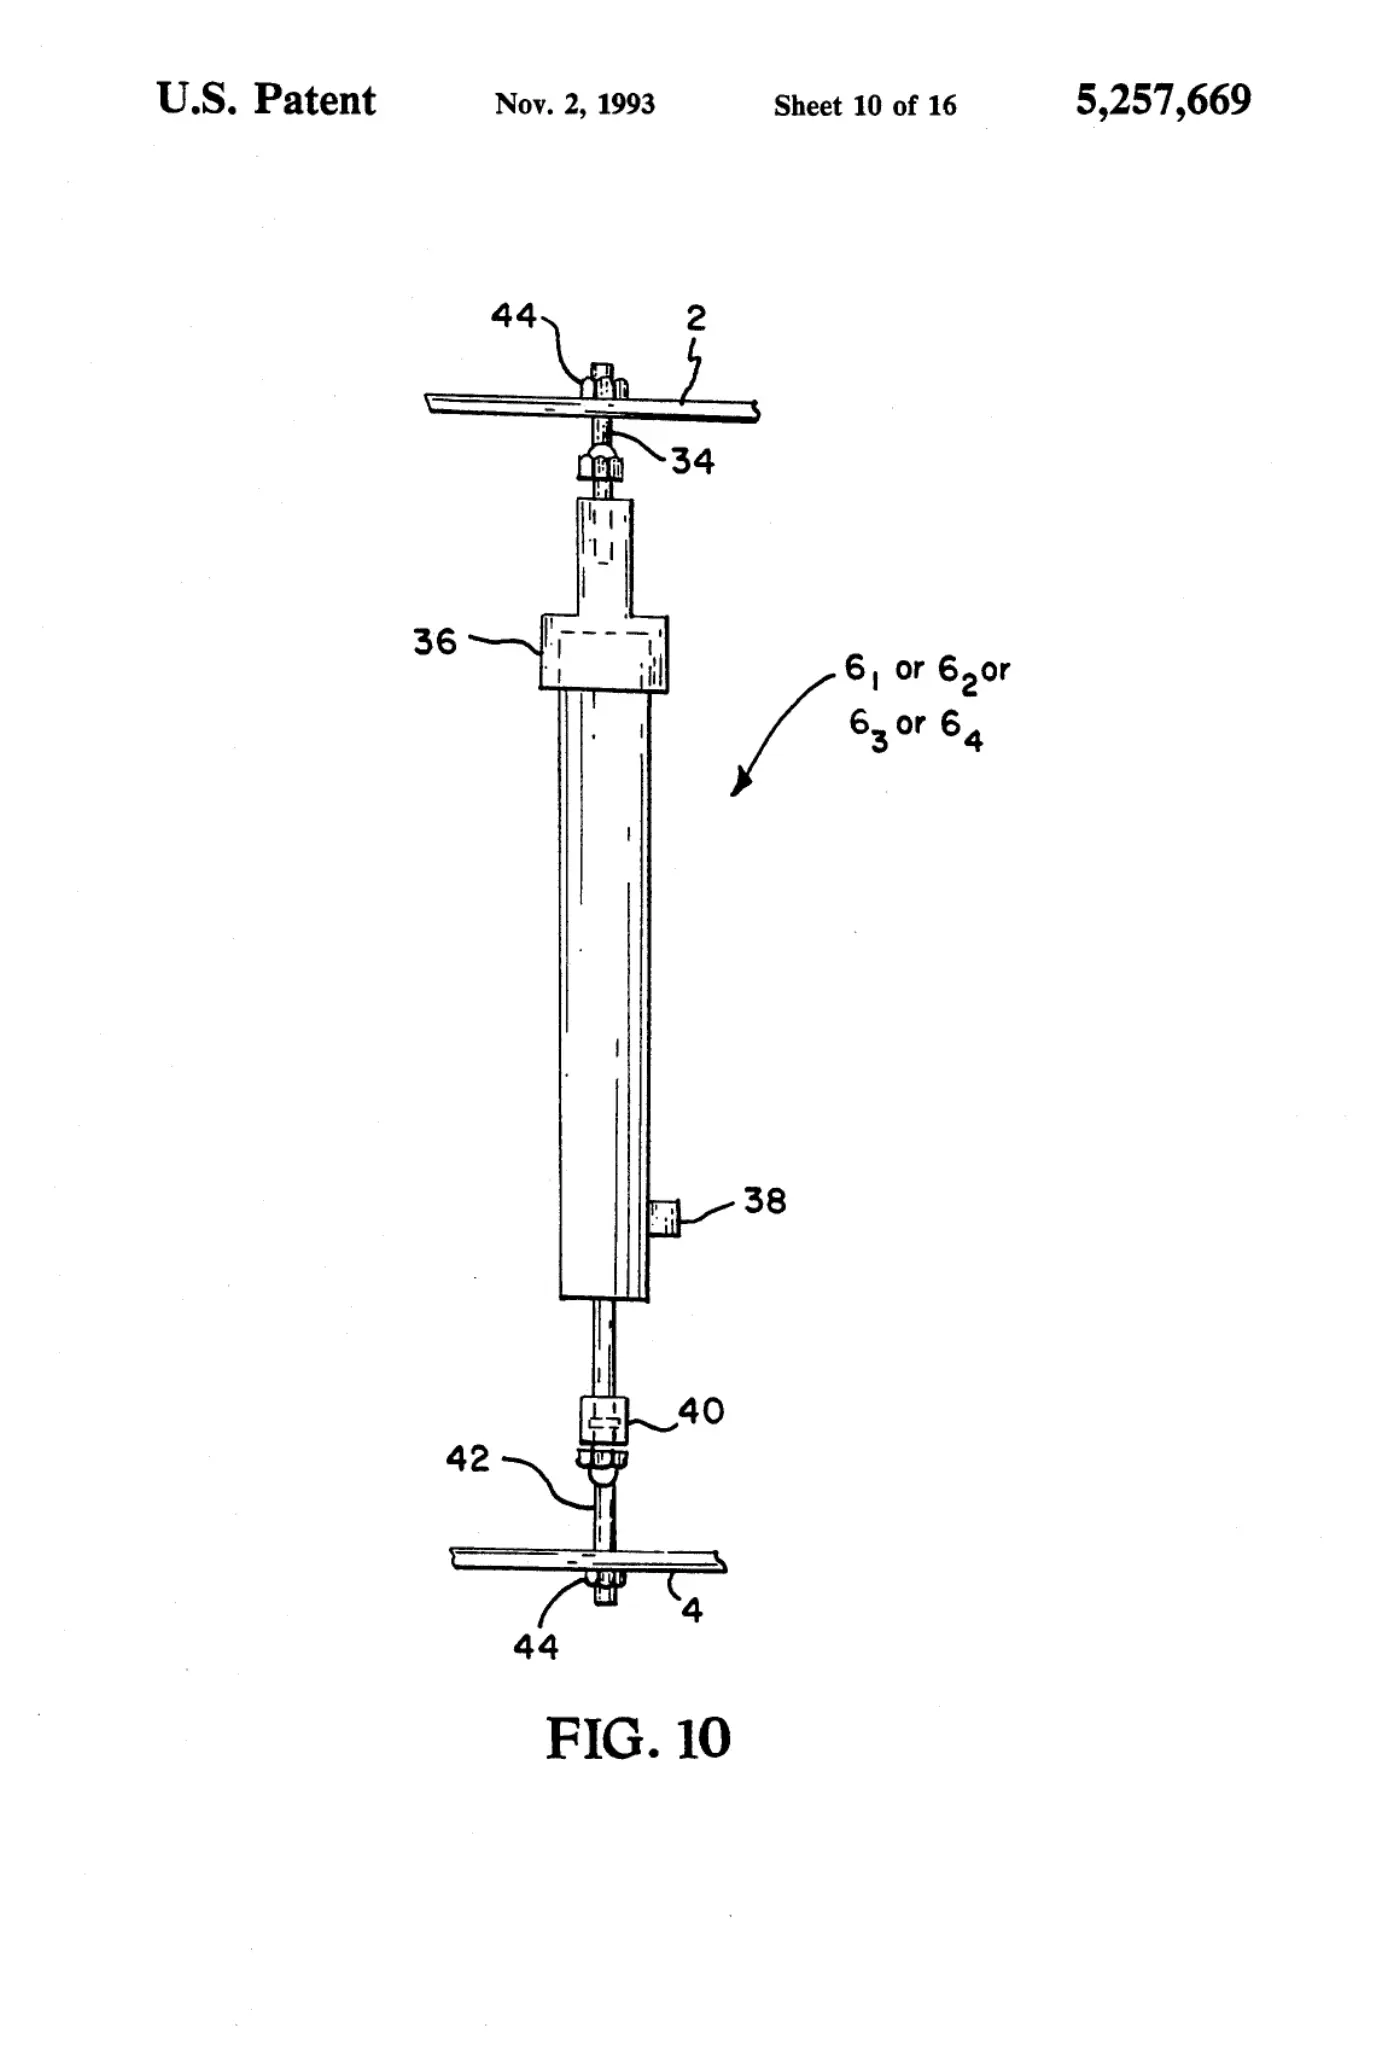
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003364, “Climbing robot,” published September 15, 2026 at 20:16:46 UTC, https://opentechnical.org/p/OT-2026-000003364.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.