OT-2026-000003387
Wrist for an industrial robot
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003387
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- AMPARORE MAURO, ORSI MARIO
- Assignee
- COMAU SPA
- Original source
- US-5178031-A, the United States Patent and Trademark Office, 12 January 1993
- Document SHA-256
- ee3a2907d640a769f7067b777fac9507e126a879fa45e346b15dc1e7a6bbb405
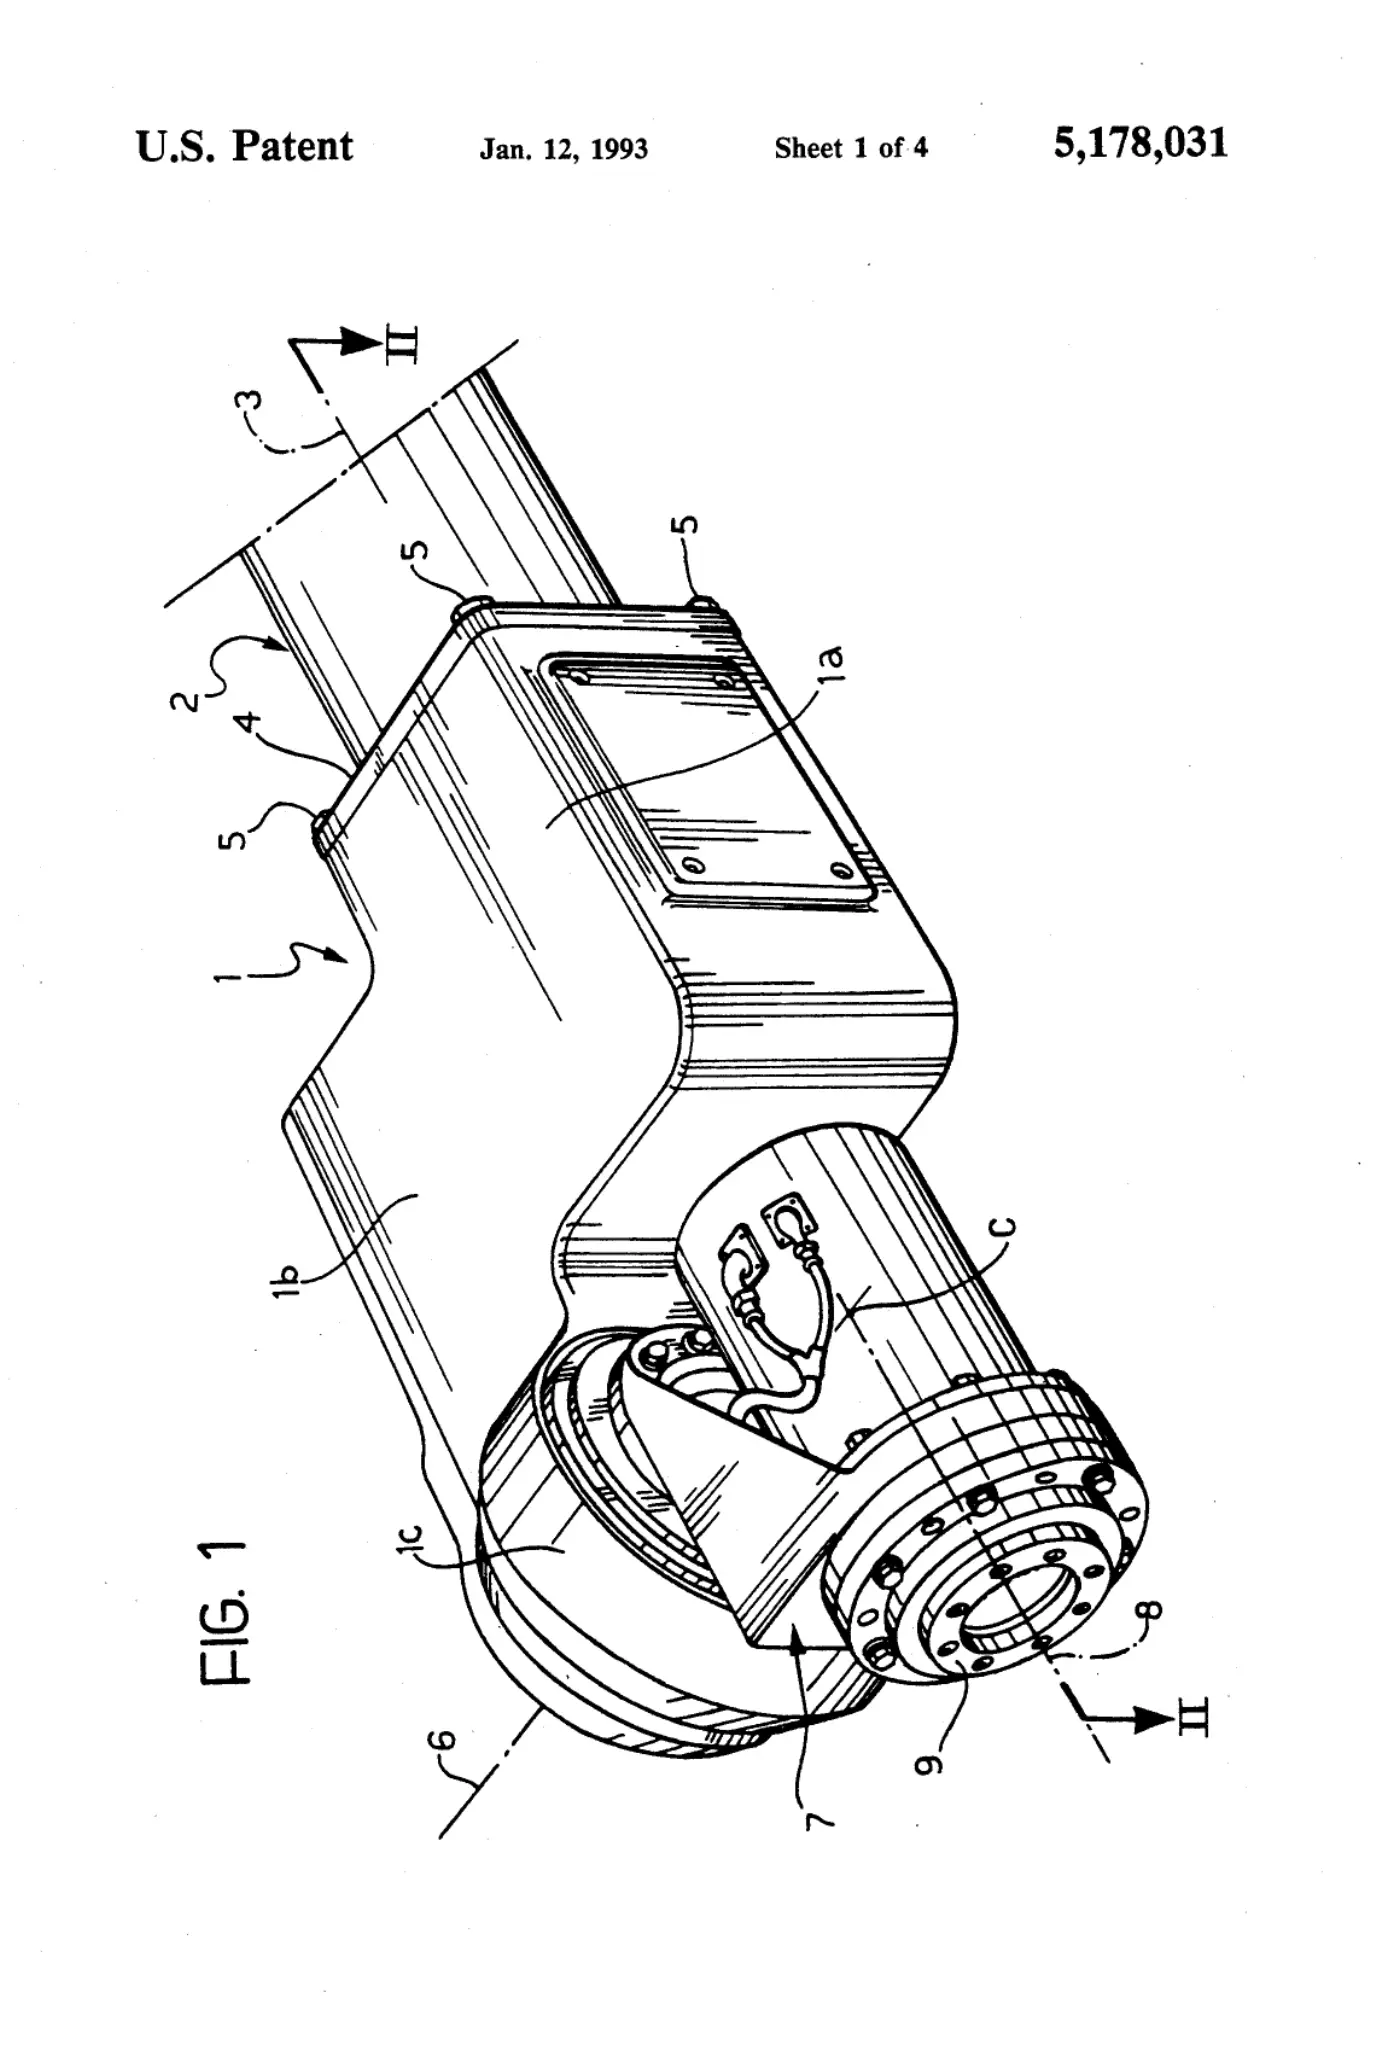
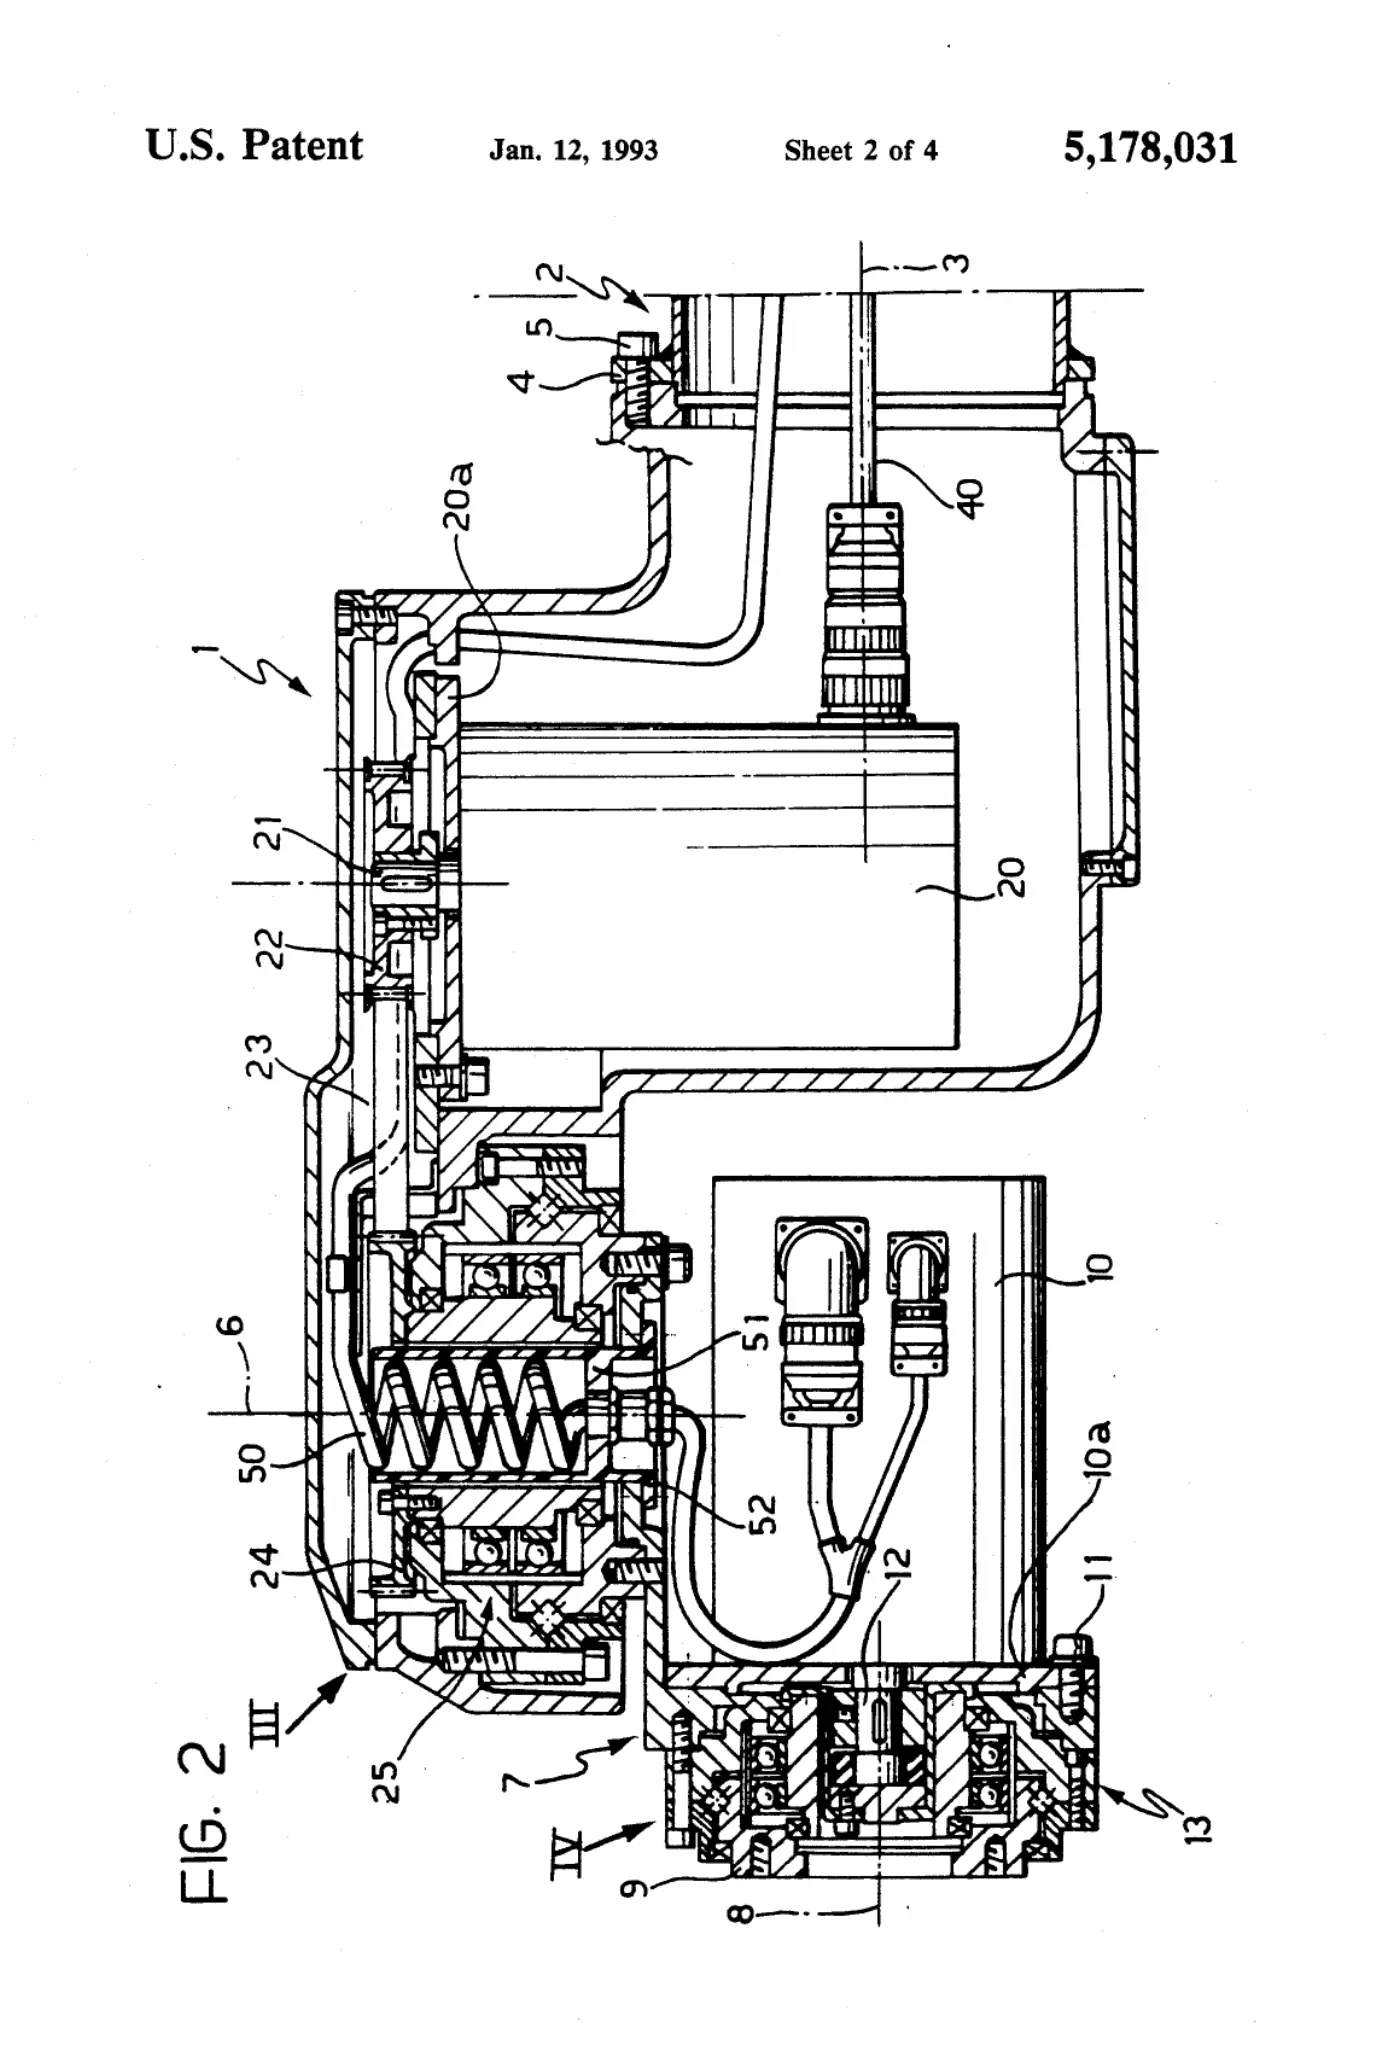
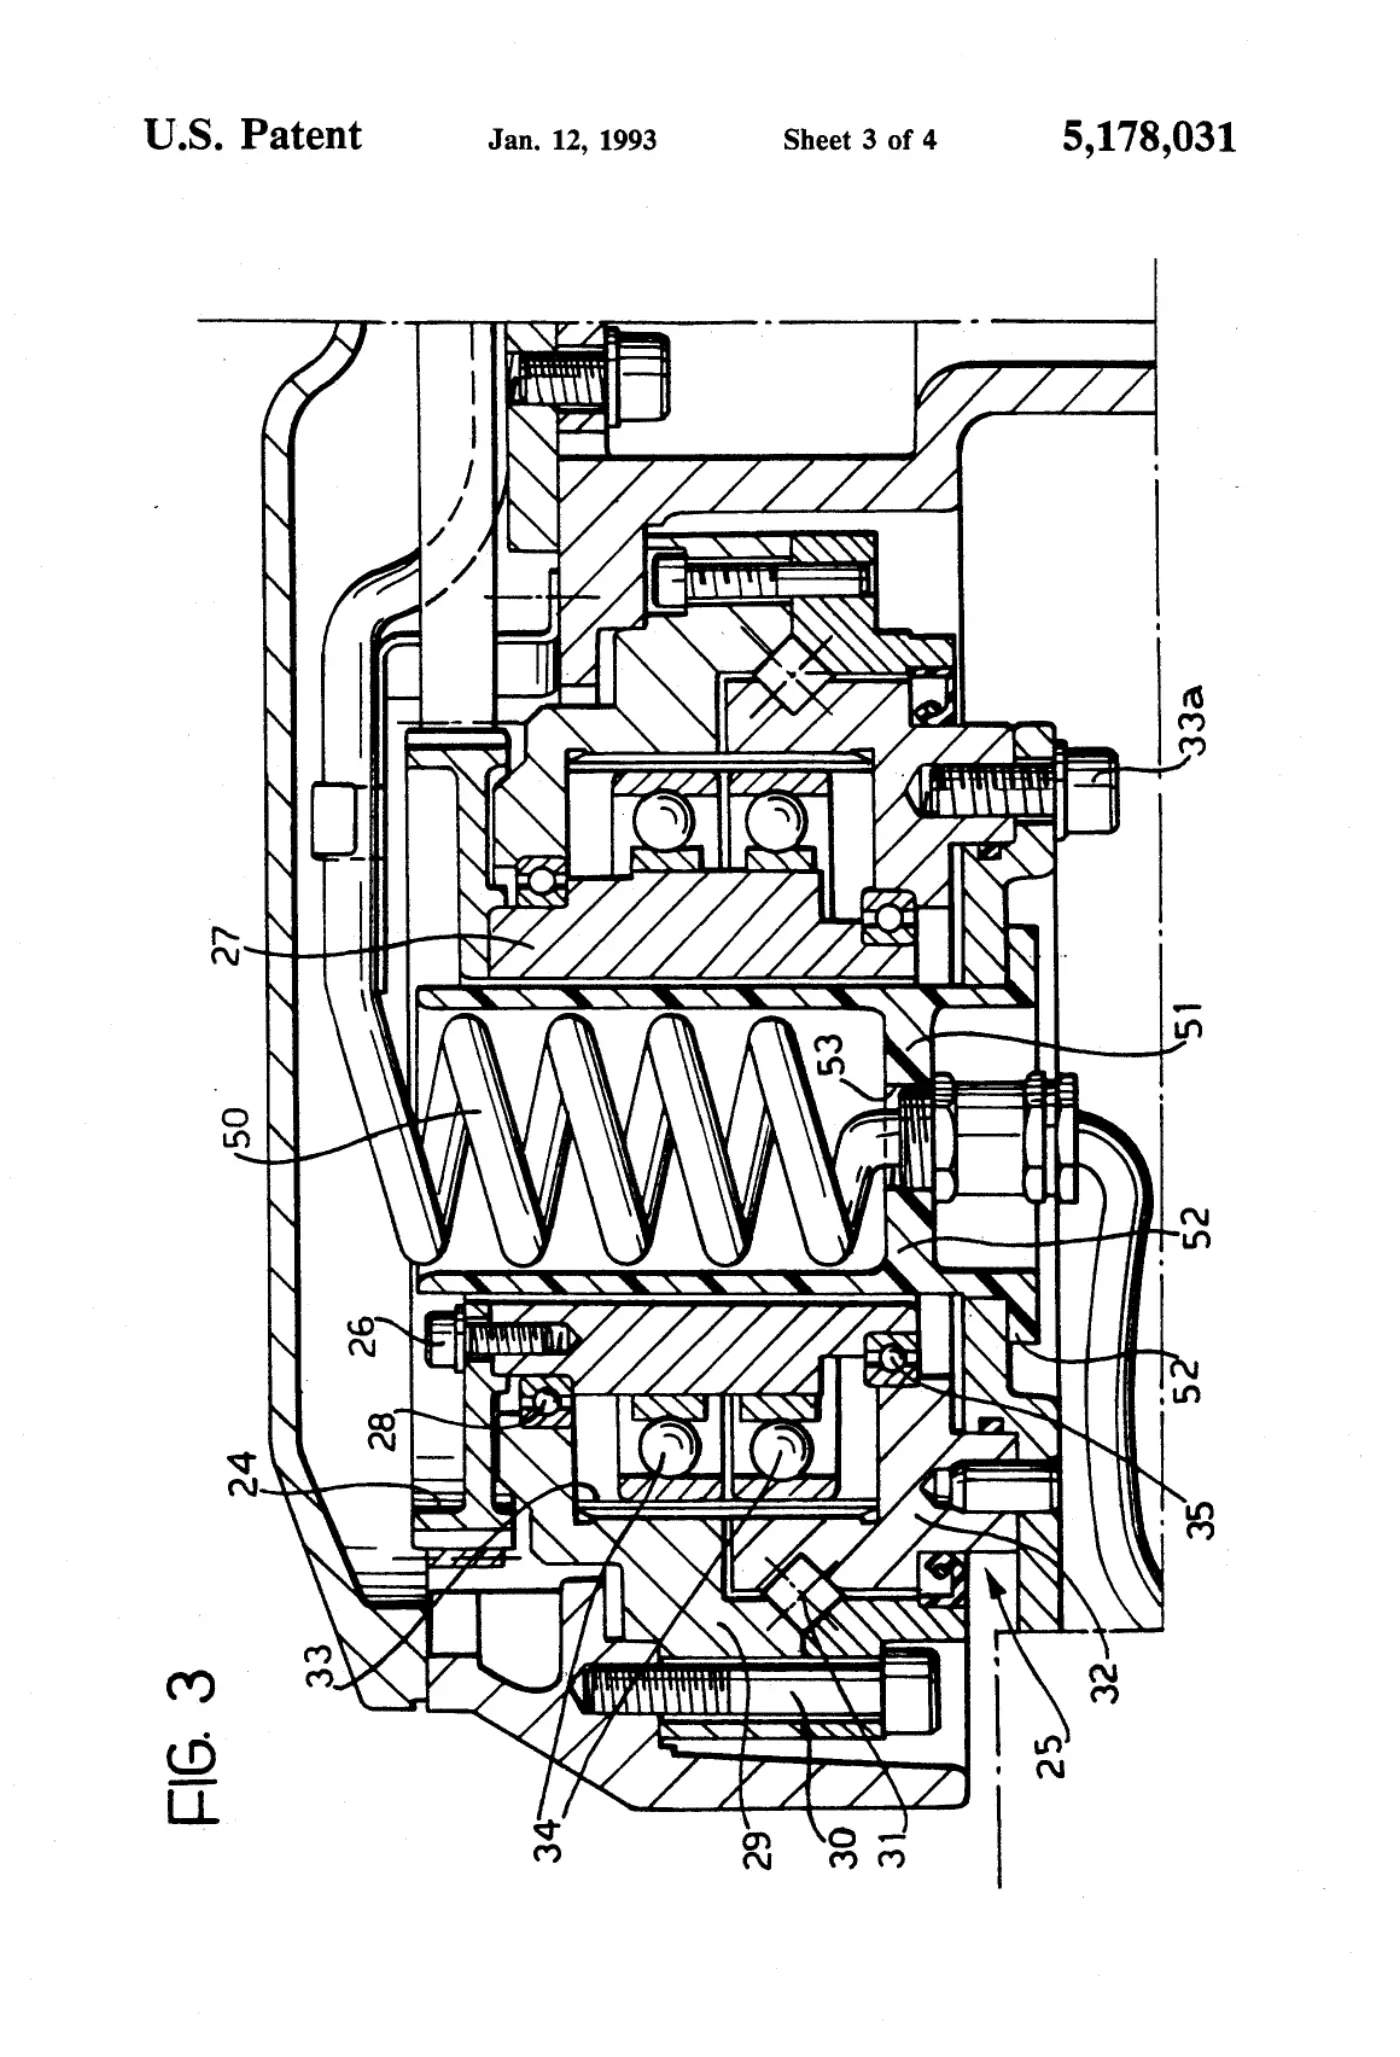
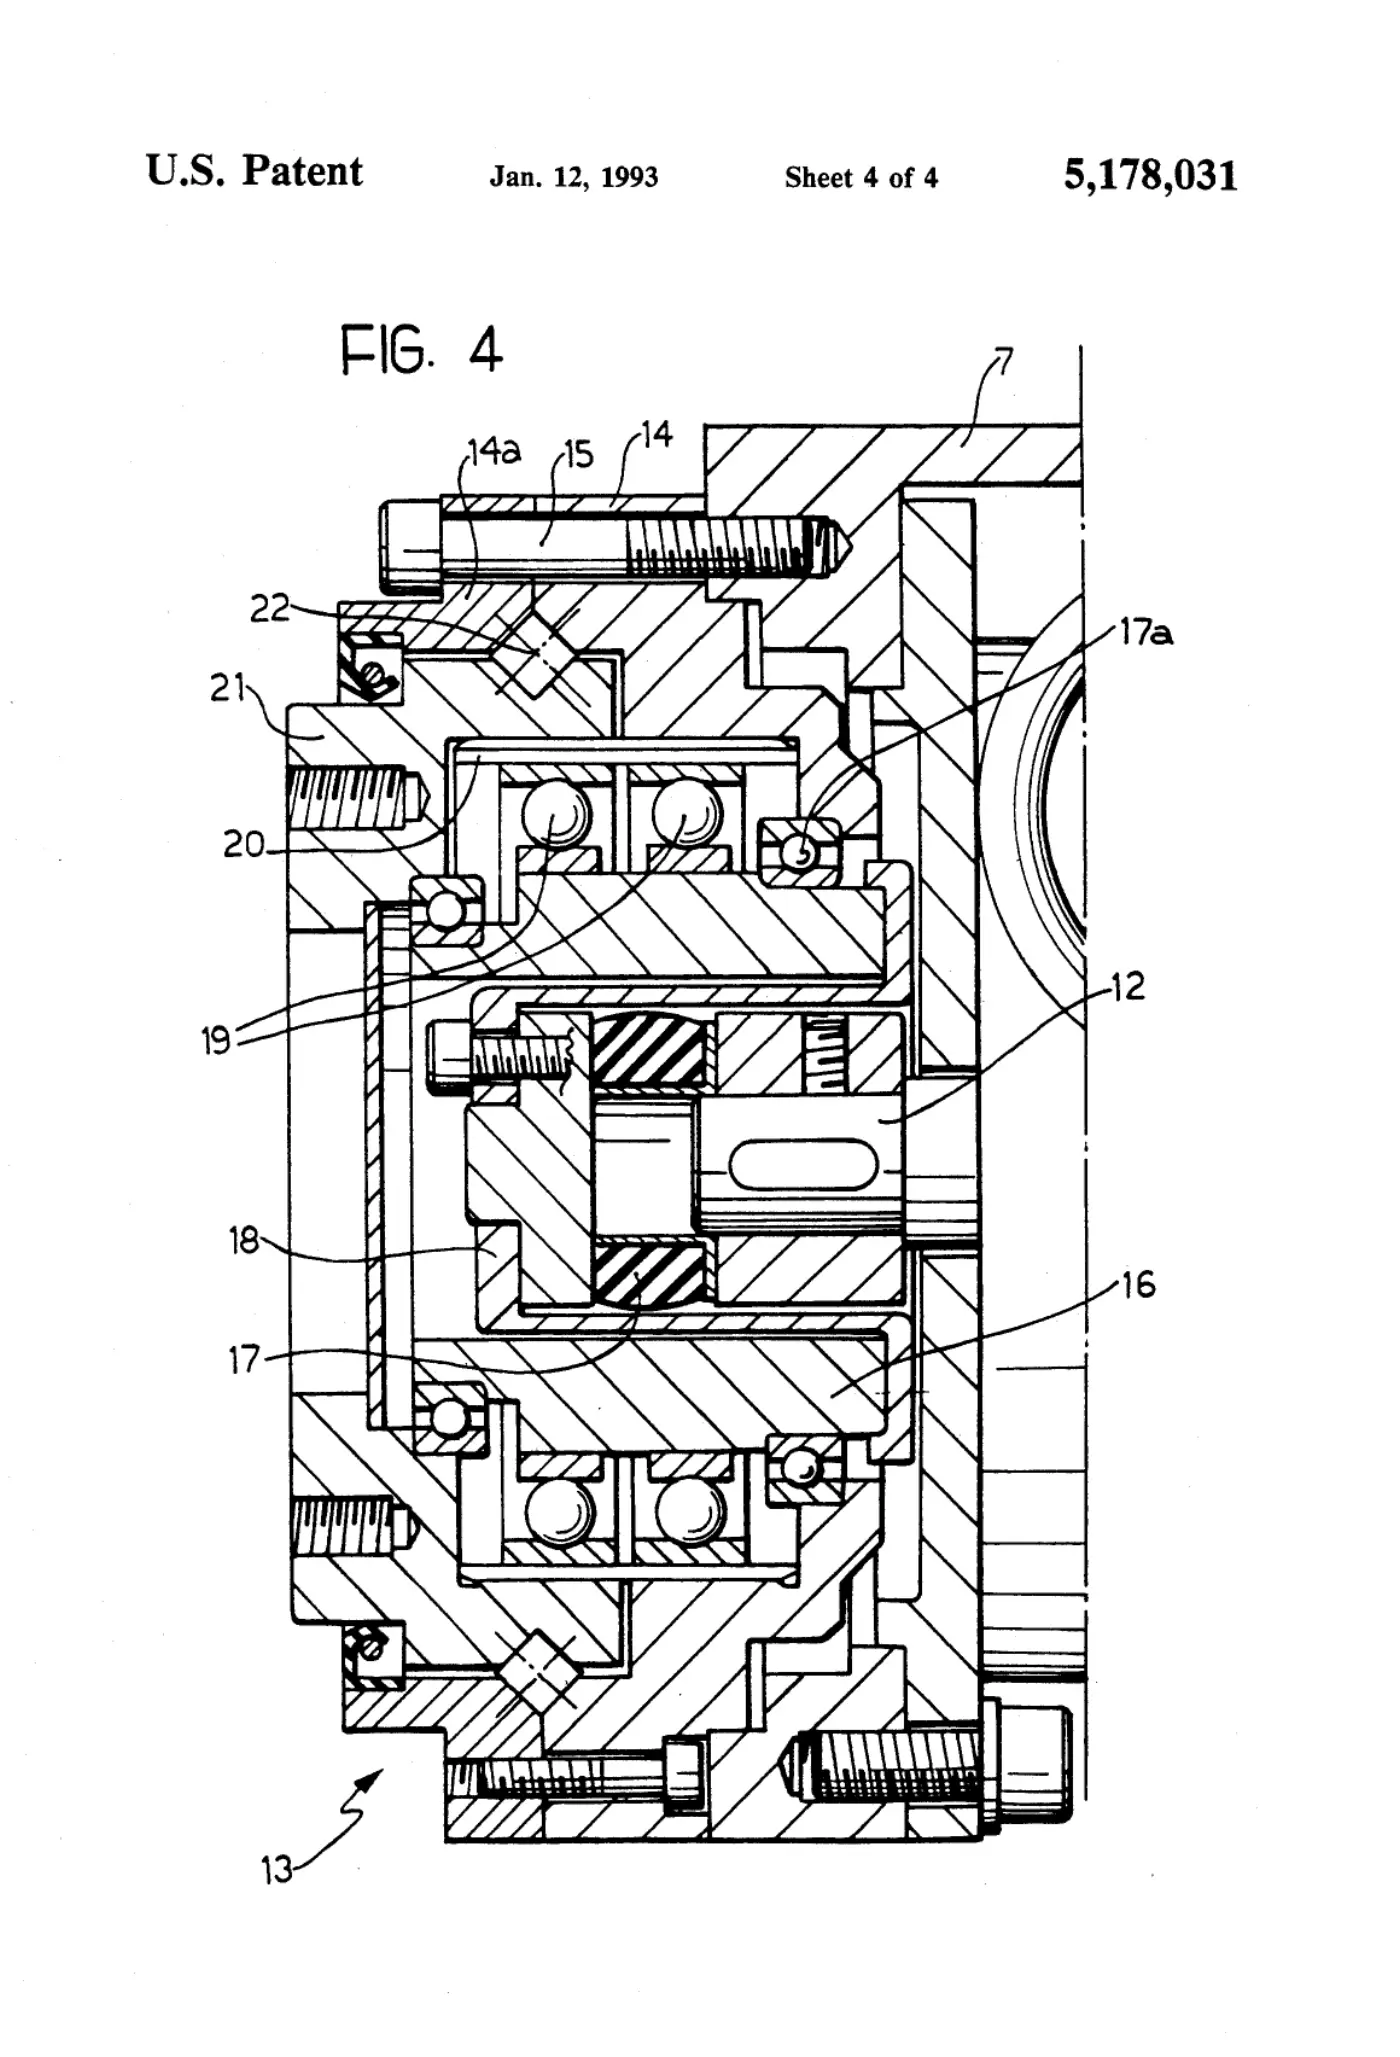
A robot wrist with two articulation axes has a first body which is carried at the distal end of the robot arm, a second body which is supported by the first body for rotation about a first axis which intersects the longitudinal axis of the robot arm at right angles, and a third body which is supported by the second body for rotation about a second axis which intersects the first axis at right angles. The second and third bodies are rotated by two electric motors which are mounted on the first body and the second body respectively, with the interposition of "Harmonic Drive" reduction units of the type in which the output rotor is supported for rotation by a load-bearing element which forms part of the reduction unit.
Abstract
A robot wrist with two articulation axes has a first body which is carried at the distal end of the robot arm, a second body which is supported by the first body for rotation about a first axis which intersects the longitudinal axis of the robot arm at right angles, and a third body which is supported by the second body for rotation about a second axis which intersects the first axis at right angles. The second and third bodies are rotated by two electric motors which are mounted on the first body and the second body respectively, with the interposition of "Harmonic Drive" reduction units of the type in which the output rotor is supported for rotation by a load-bearing element which forms part of the reduction unit.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
Publication information
Citation
OpenTechnical Publication OT-2026-000003387, “Wrist for an industrial robot,” published September 15, 2026 at 20:20:02 UTC, https://opentechnical.org/p/OT-2026-000003387.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.