OT-2026-000003390
Self aligning vacuum nozzle
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003390
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- KOU YUEN-FOO M, KOWALESKI KELLI L, ROBERTS GARY D
- Assignee
- DIGITAL EQUIPMENT CORP
- Original source
- US-5172922-A, the United States Patent and Trademark Office, 22 December 1992
- Document SHA-256
- ee7ef89215007cfffc5359ff46740e062f742eba3f06ee32359c937361159497
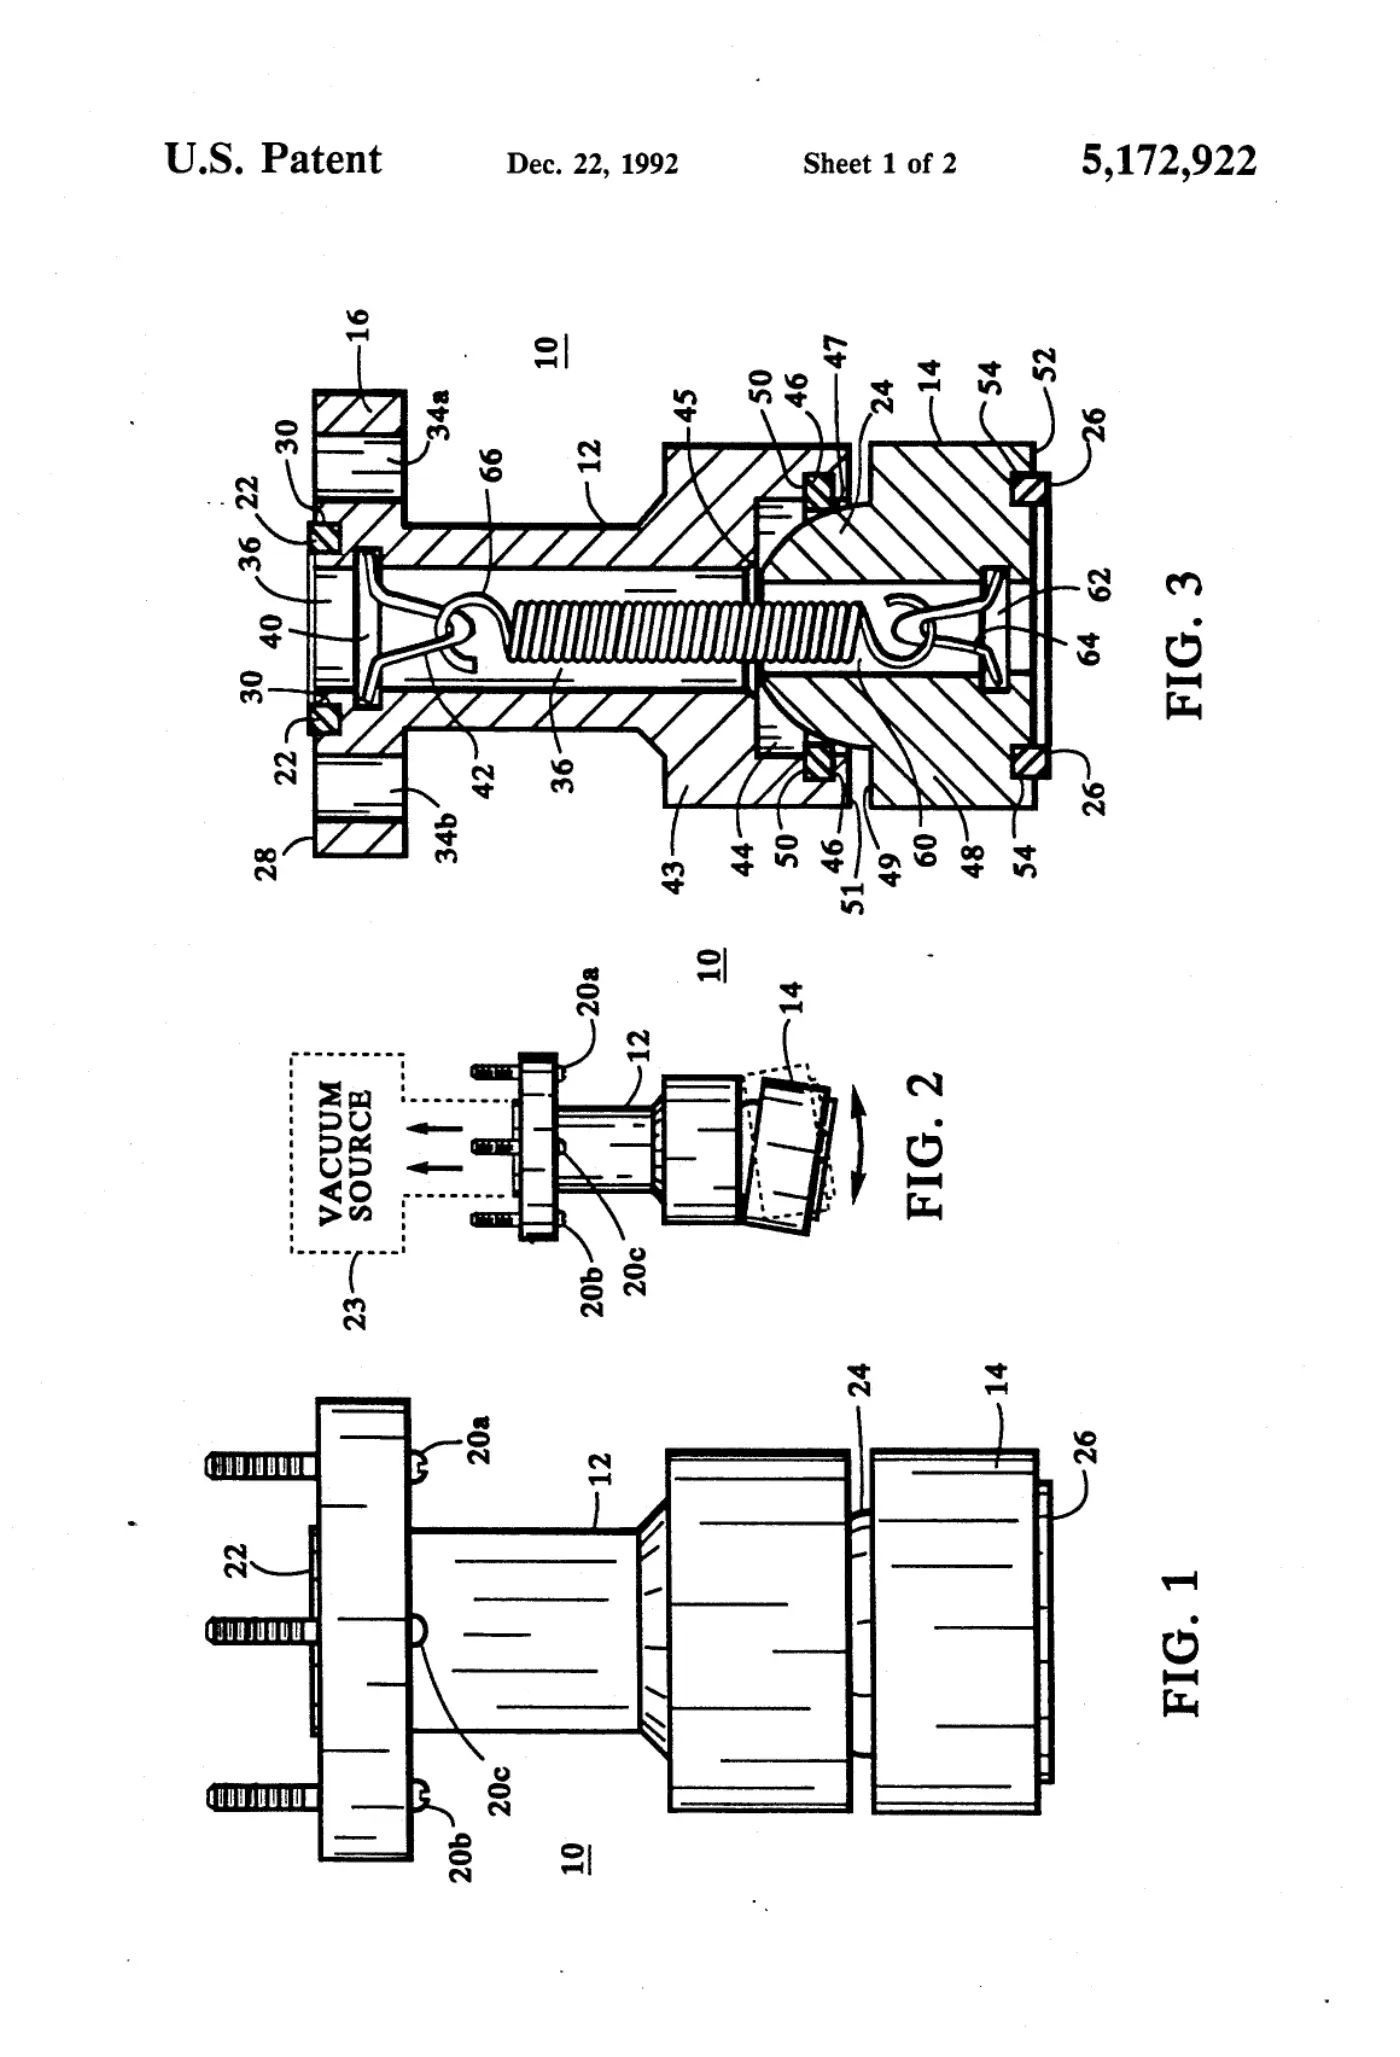
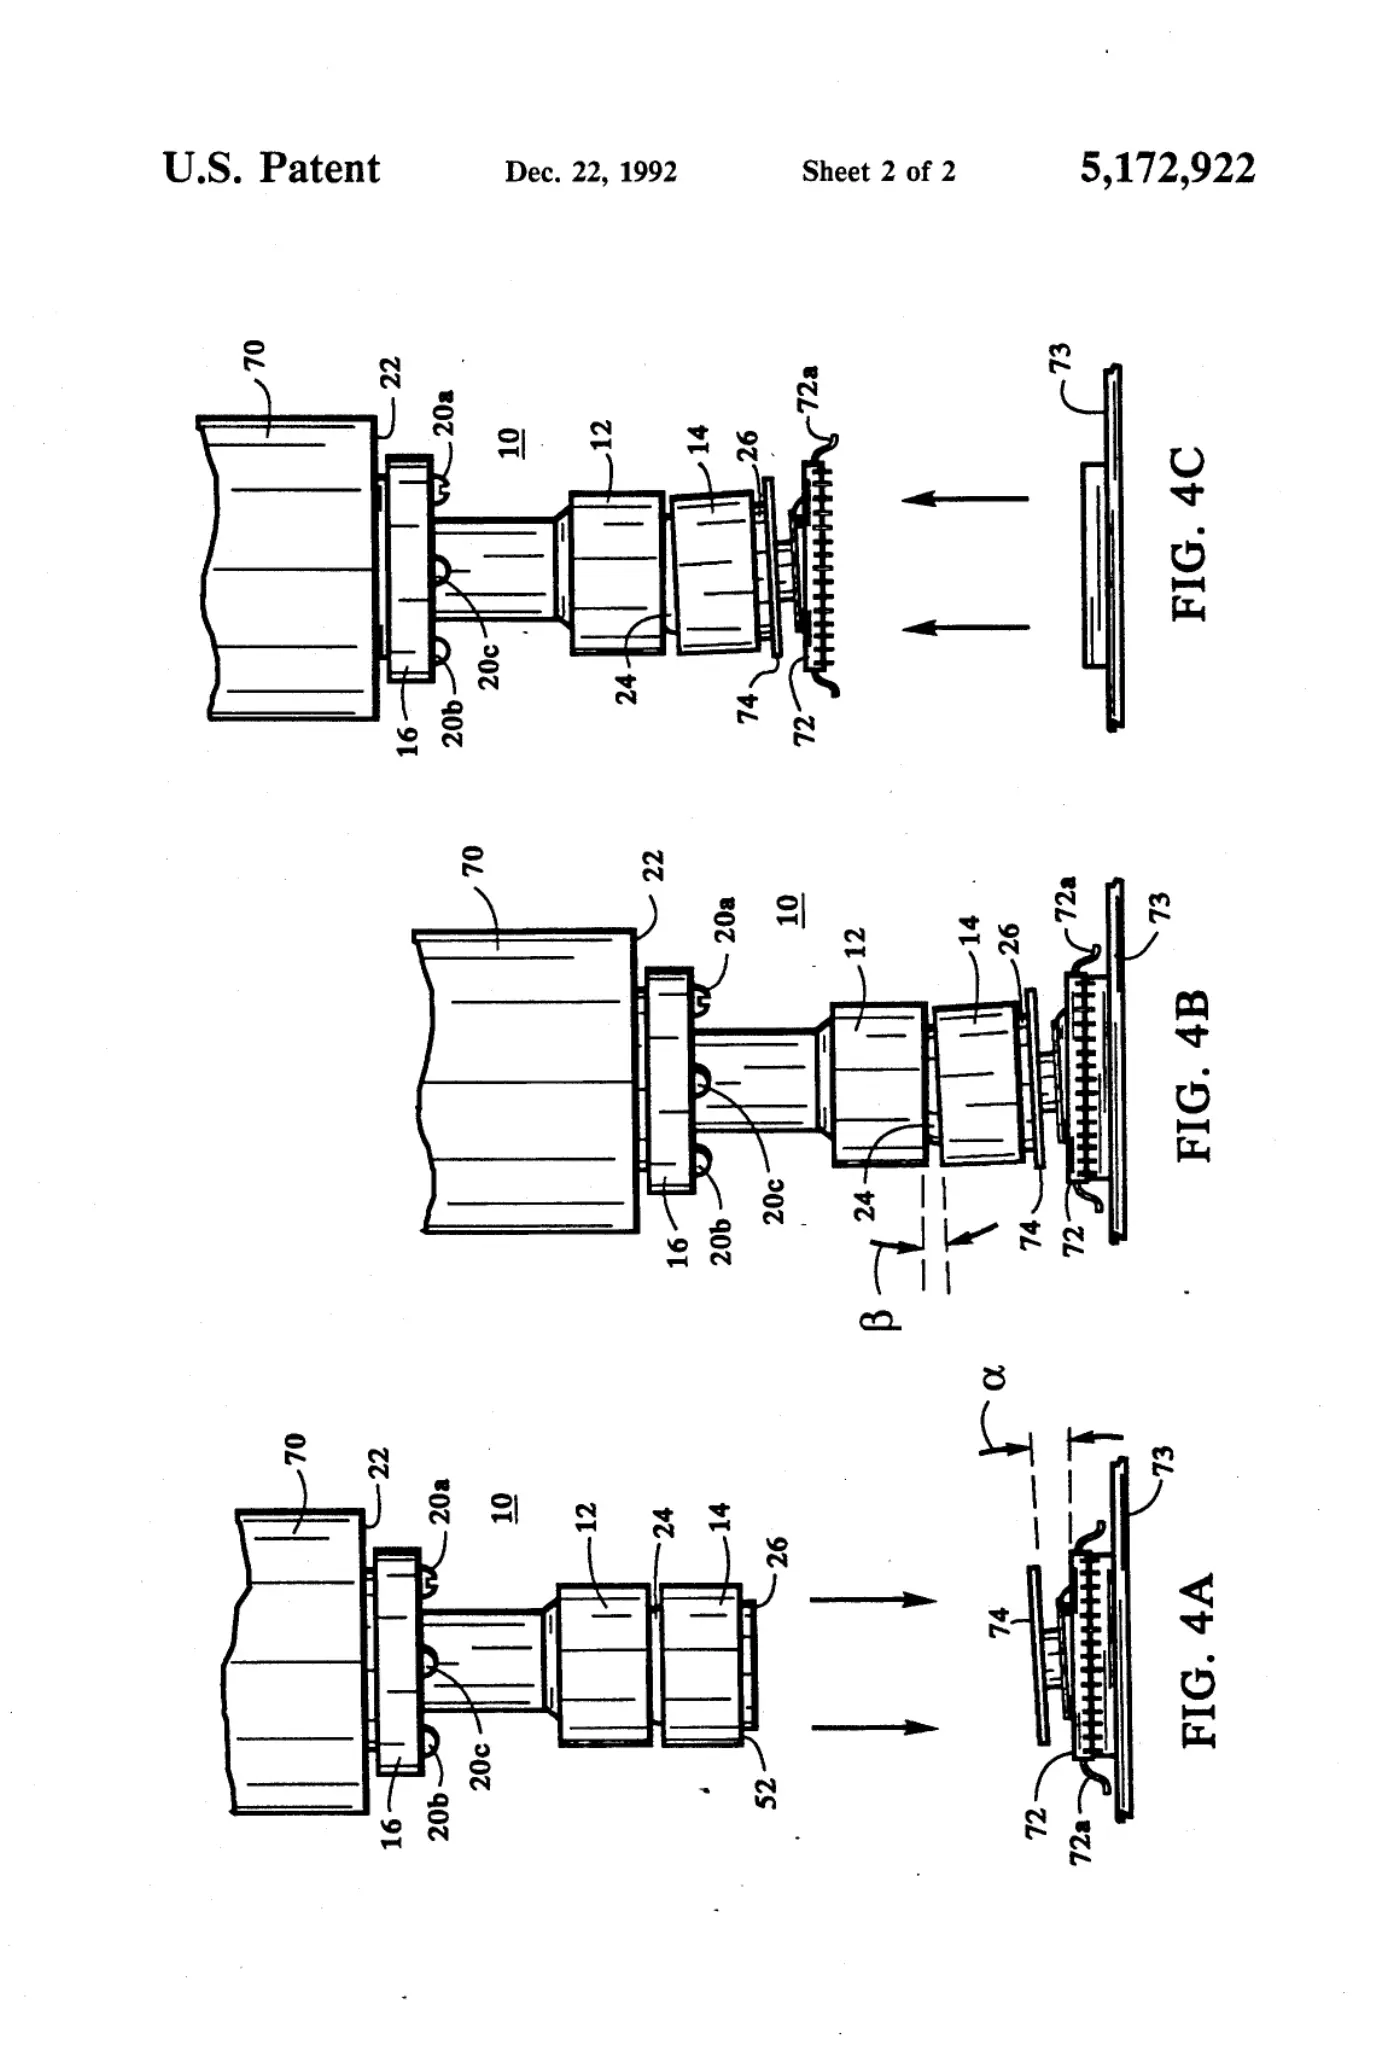
This invention relates to a self aligning, vacuum end effector which is capable of picking up objects which have a pick up surface which is not planar with the pick up surface of the end effector. The end effector is comprised of two parts: a nozzle base which fixedly attaches to an automatic assembly device, such as robotic arm; and a nozzle tip, which is the part of the end effector which actually comes in contact with the object to be picked up. The nozzle base and nozzle tip are secured together by a retention spring. The nozzle tip has a generally, semi-spherically shaped ball portion which is partly inserted into a bore within the nozzle base and rests against a quad ring which is secured within the bore. Consequently, when the nozzle tip makes contact with an object which is to be picked up and moved, the semi-spherical ball portion of the nozzle tip slides against the quad ring and the nozzle tip pivotally moves and aligns itself with the plane of the surface of the object to be picked up. Hollowed through the center of both parts of the end effector is a passageway through which a vacuum source supplied by the robotic arm can be effected at the contact surface of the nozzle tip, so that the object can be picked up.
Abstract
This invention relates to a self aligning, vacuum end effector which is capable of picking up objects which have a pick up surface which is not planar with the pick up surface of the end effector. The end effector is comprised of two parts: a nozzle base which fixedly attaches to an automatic assembly device, such as robotic arm; and a nozzle tip, which is the part of the end effector which actually comes in contact with the object to be picked up. The nozzle base and nozzle tip are secured together by a retention spring. The nozzle tip has a generally, semi-spherically shaped ball portion which is partly inserted into a bore within the nozzle base and rests against a quad ring which is secured within the bore. Consequently, when the nozzle tip makes contact with an object which is to be picked up and moved, the semi-spherical ball portion of the nozzle tip slides against the quad ring and the nozzle tip pivotally moves and aligns itself with the plane of the surface of the object to be picked up. Hollowed through the center of both parts of the end effector is a passageway through which a vacuum source supplied by the robotic arm can be effected at the contact surface of the nozzle tip, so that the object can be picked up.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
Publication information
Citation
OpenTechnical Publication OT-2026-000003390, “Self aligning vacuum nozzle,” published September 15, 2026 at 20:20:31 UTC, https://opentechnical.org/p/OT-2026-000003390.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.