OT-2026-000003413
Hydraulic control system
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003413
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- FRENETTE REAL N, LAWRENCE PETER D
- Assignee
- UNIV BRITISH COLUMBIA
- Original source
- US-5062264-A, the United States Patent and Trademark Office, 5 November 1991
- Document SHA-256
- 54c3551b4baaf7de8c490eb8412a63bf0768bb8c71f4597d444cedf75019ed8a
An articulated arm employs a controller to generate δr, δΘ and δz signals for controlling the movement of the arm in r, Θ and z directions to product movement of an end point from an initial location along a desired path toward a desired location. The actual location is determined by sensing the relationships between the arm segments and determining the actual location of the end point. The actual location is continuously compared with the desired location represented by the r, Θ and z signals and, if the difference between the actual location and desired location exceeds preselected limits, the δr, δΘ and δz are scaled down thereby redefining the desired location to ensure that the actual arm movement does not lag an unacceptable amount relative to the desired location.
Abstract
An articulated arm employs a controller to generate δr, δΘ and δz signals for controlling the movement of the arm in r, Θ and z directions to product movement of an end point from an initial location along a desired path toward a desired location. The actual location is determined by sensing the relationships between the arm segments and determining the actual location of the end point. The actual location is continuously compared with the desired location represented by the r, Θ and z signals and, if the difference between the actual location and desired location exceeds preselected limits, the δr, δΘ and δz are scaled down thereby redefining the desired location to ensure that the actual arm movement does not lag an unacceptable amount relative to the desired location.
1. Drawings
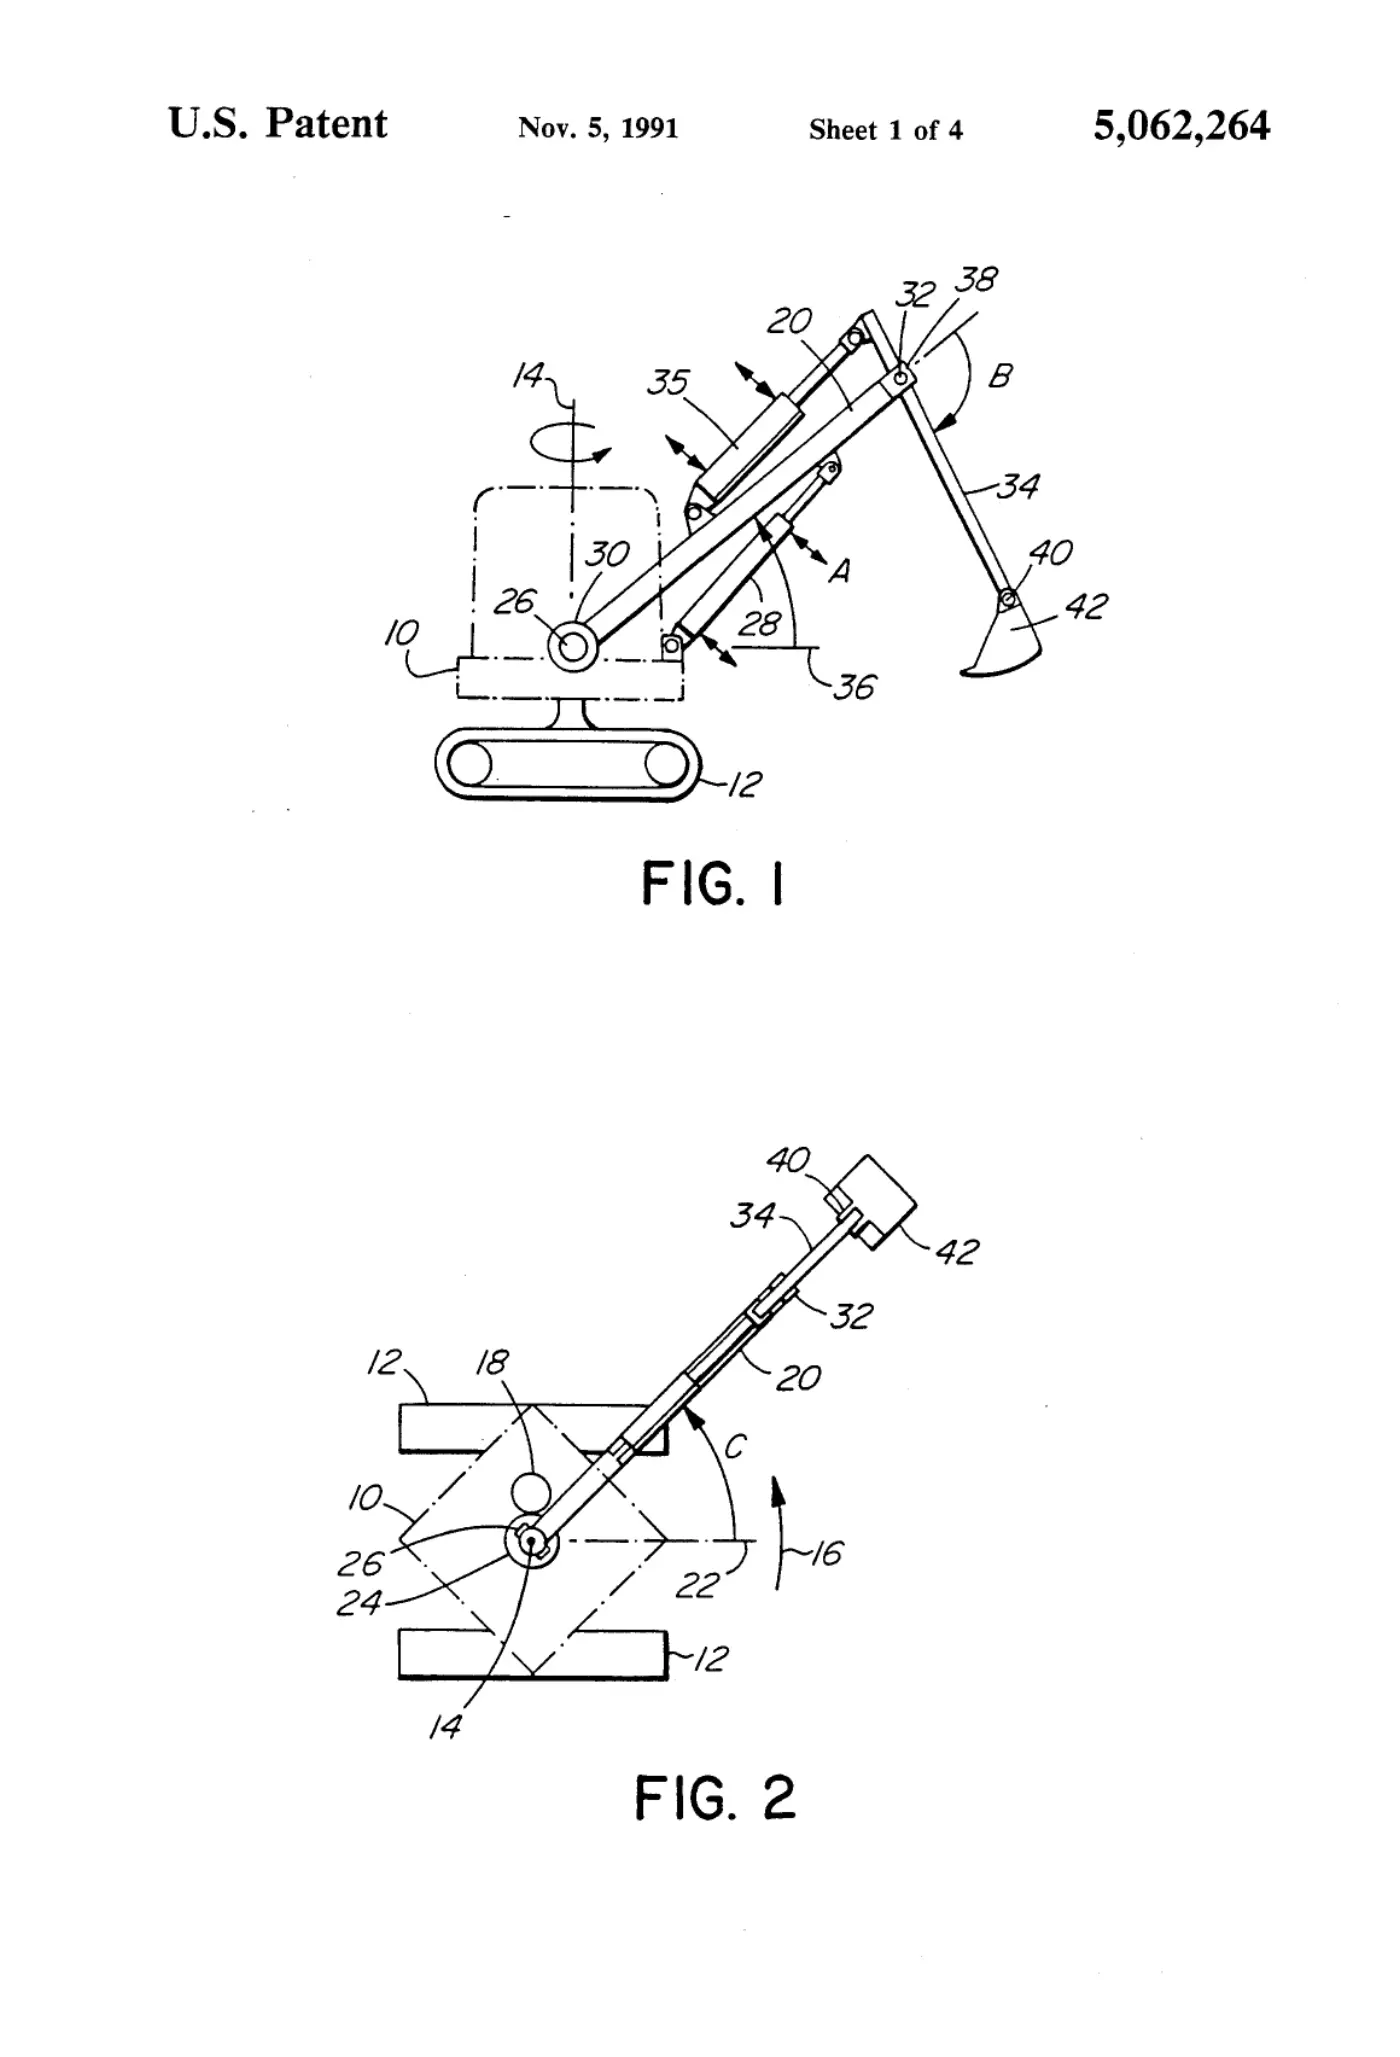
[0001]Sheet 1.
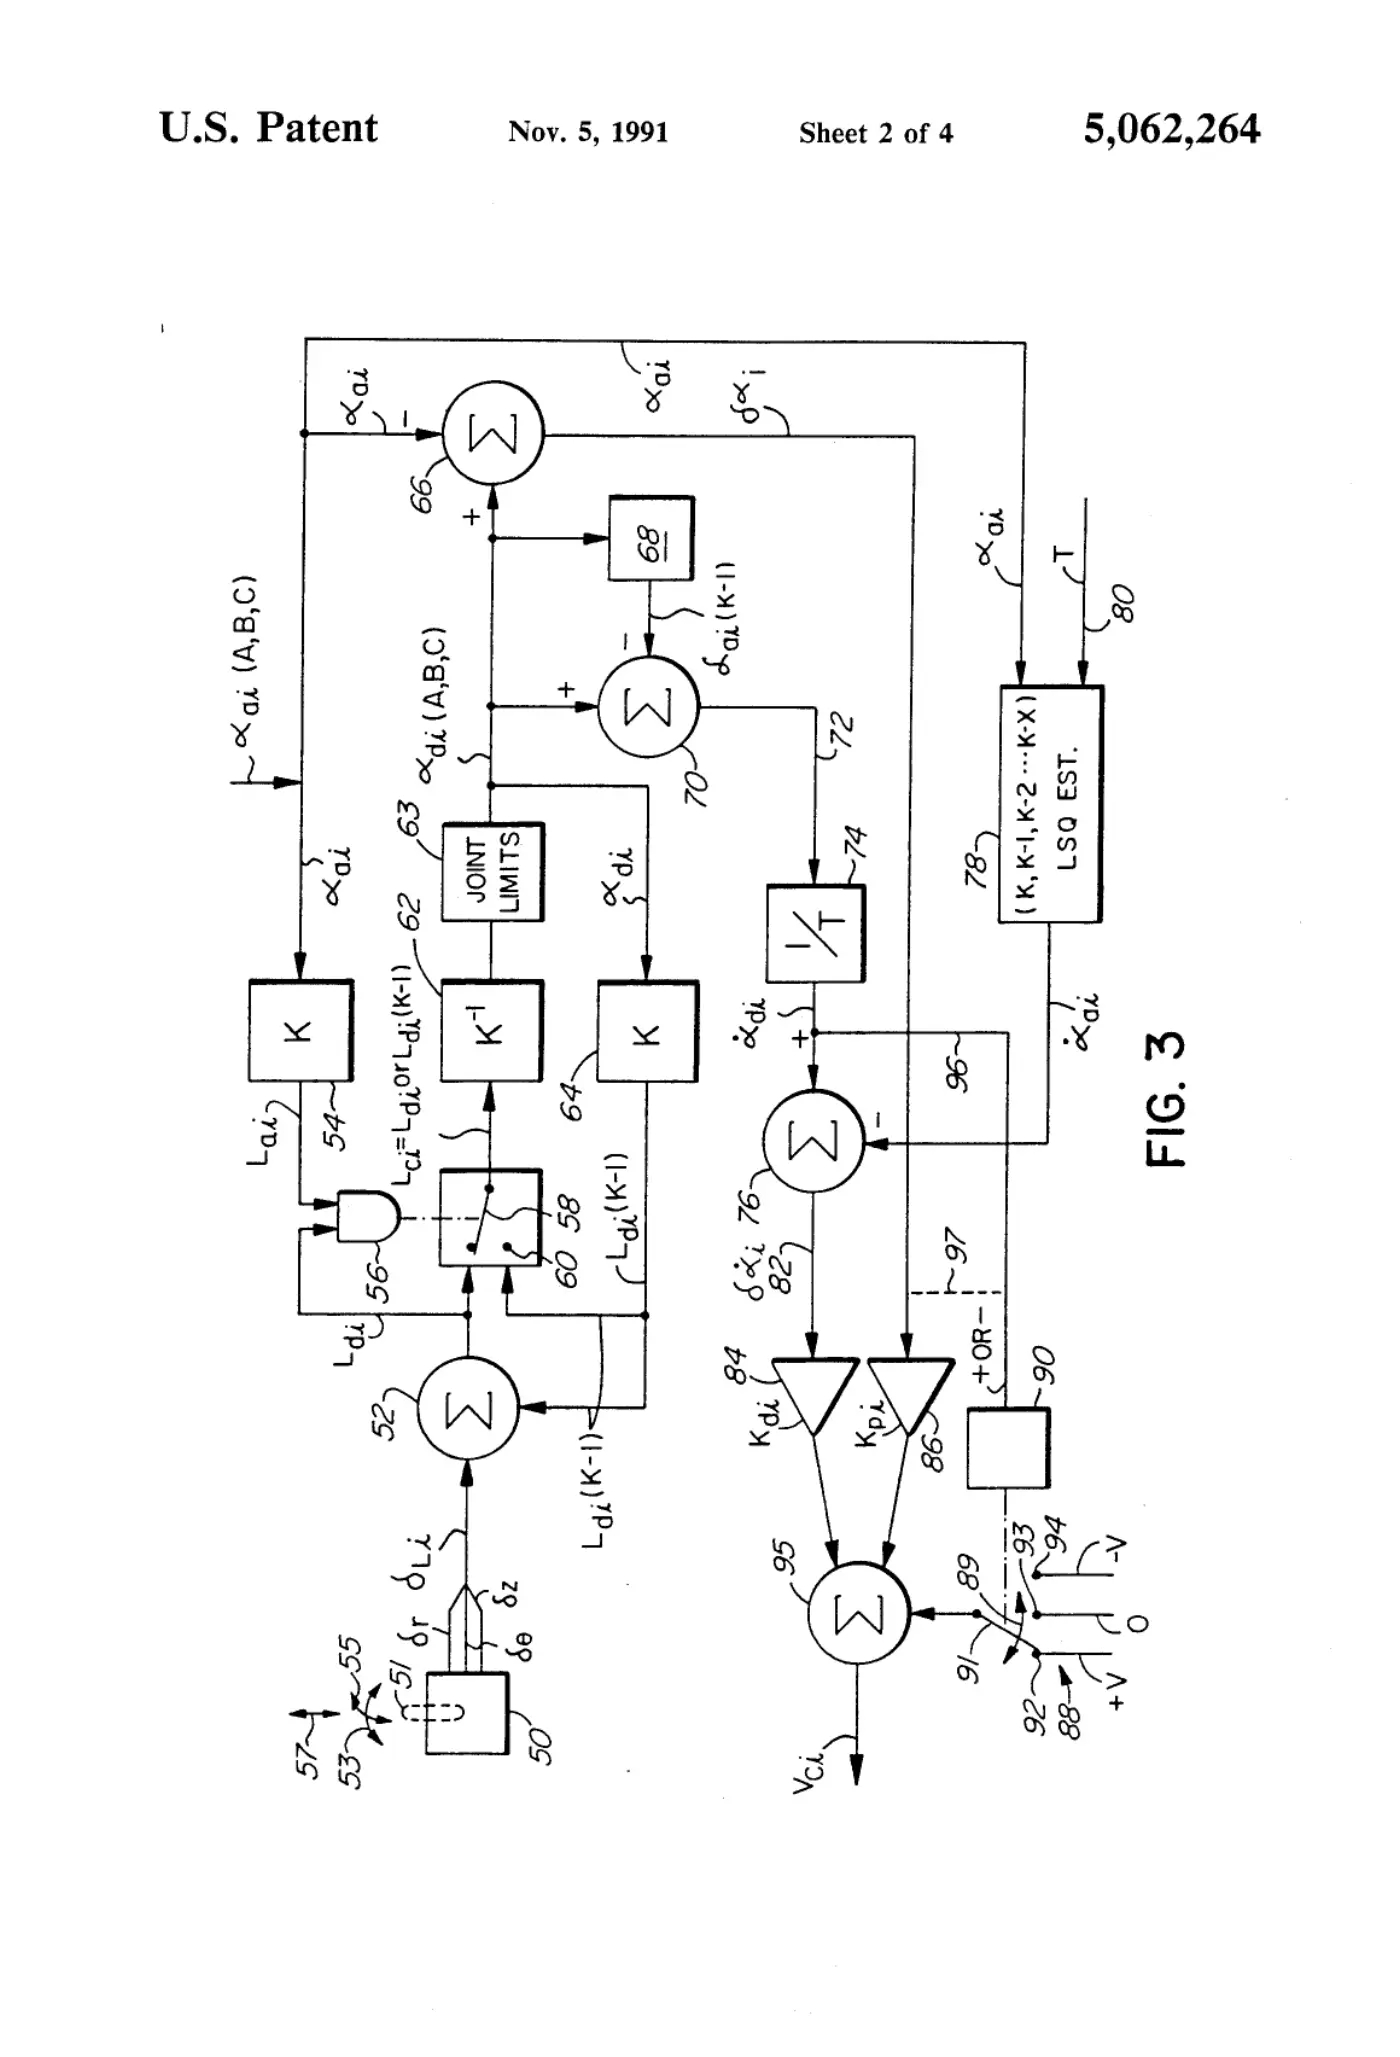
[0002]Sheet 2.
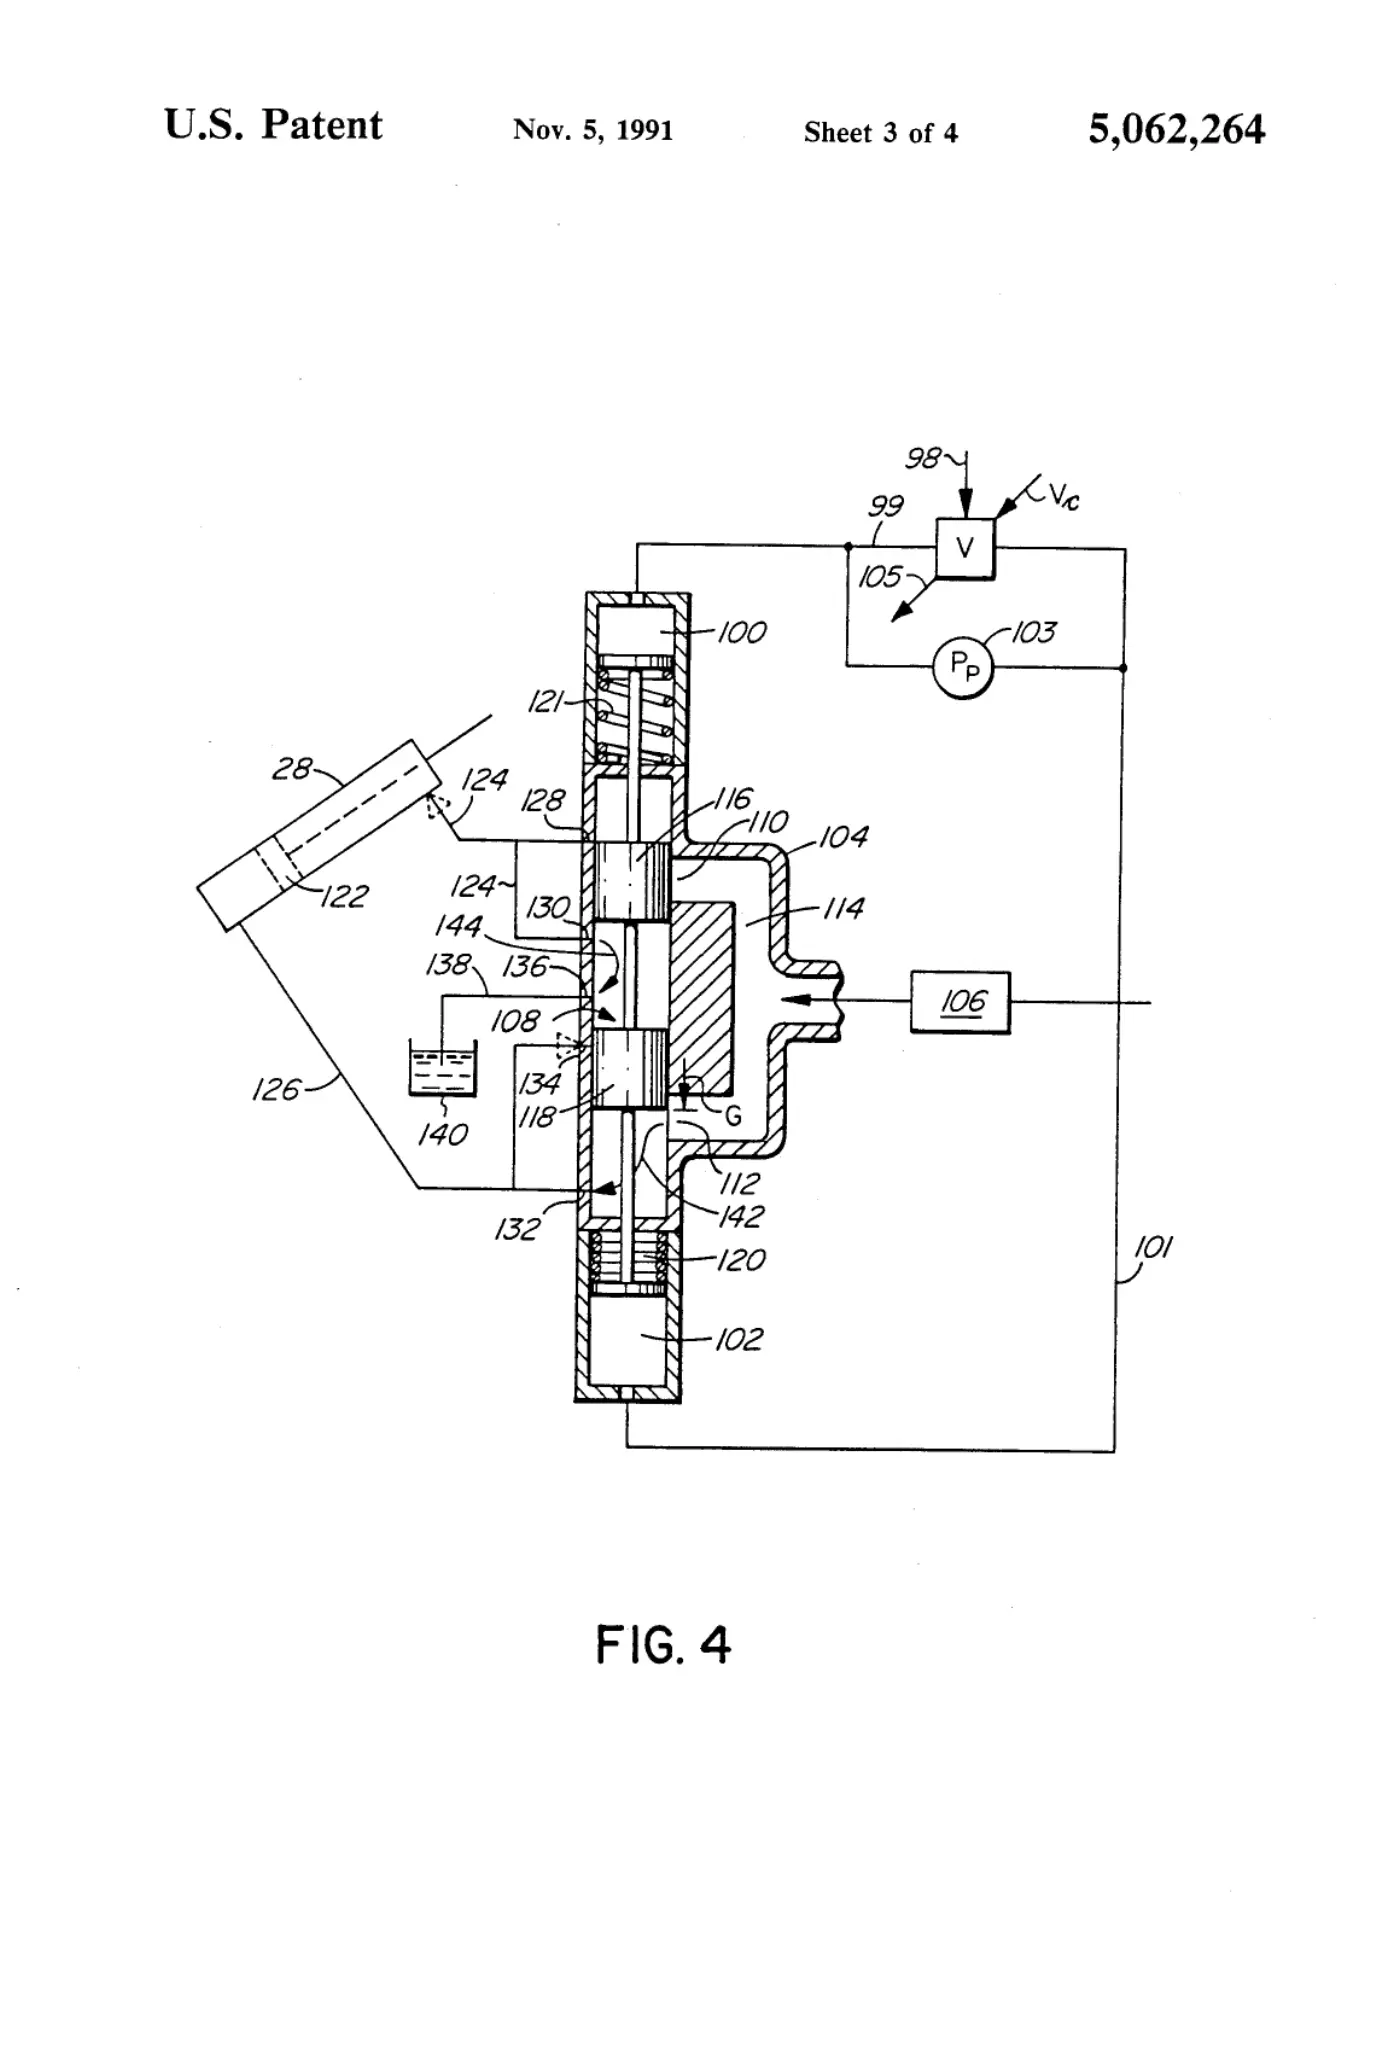
[0003]Sheet 3.
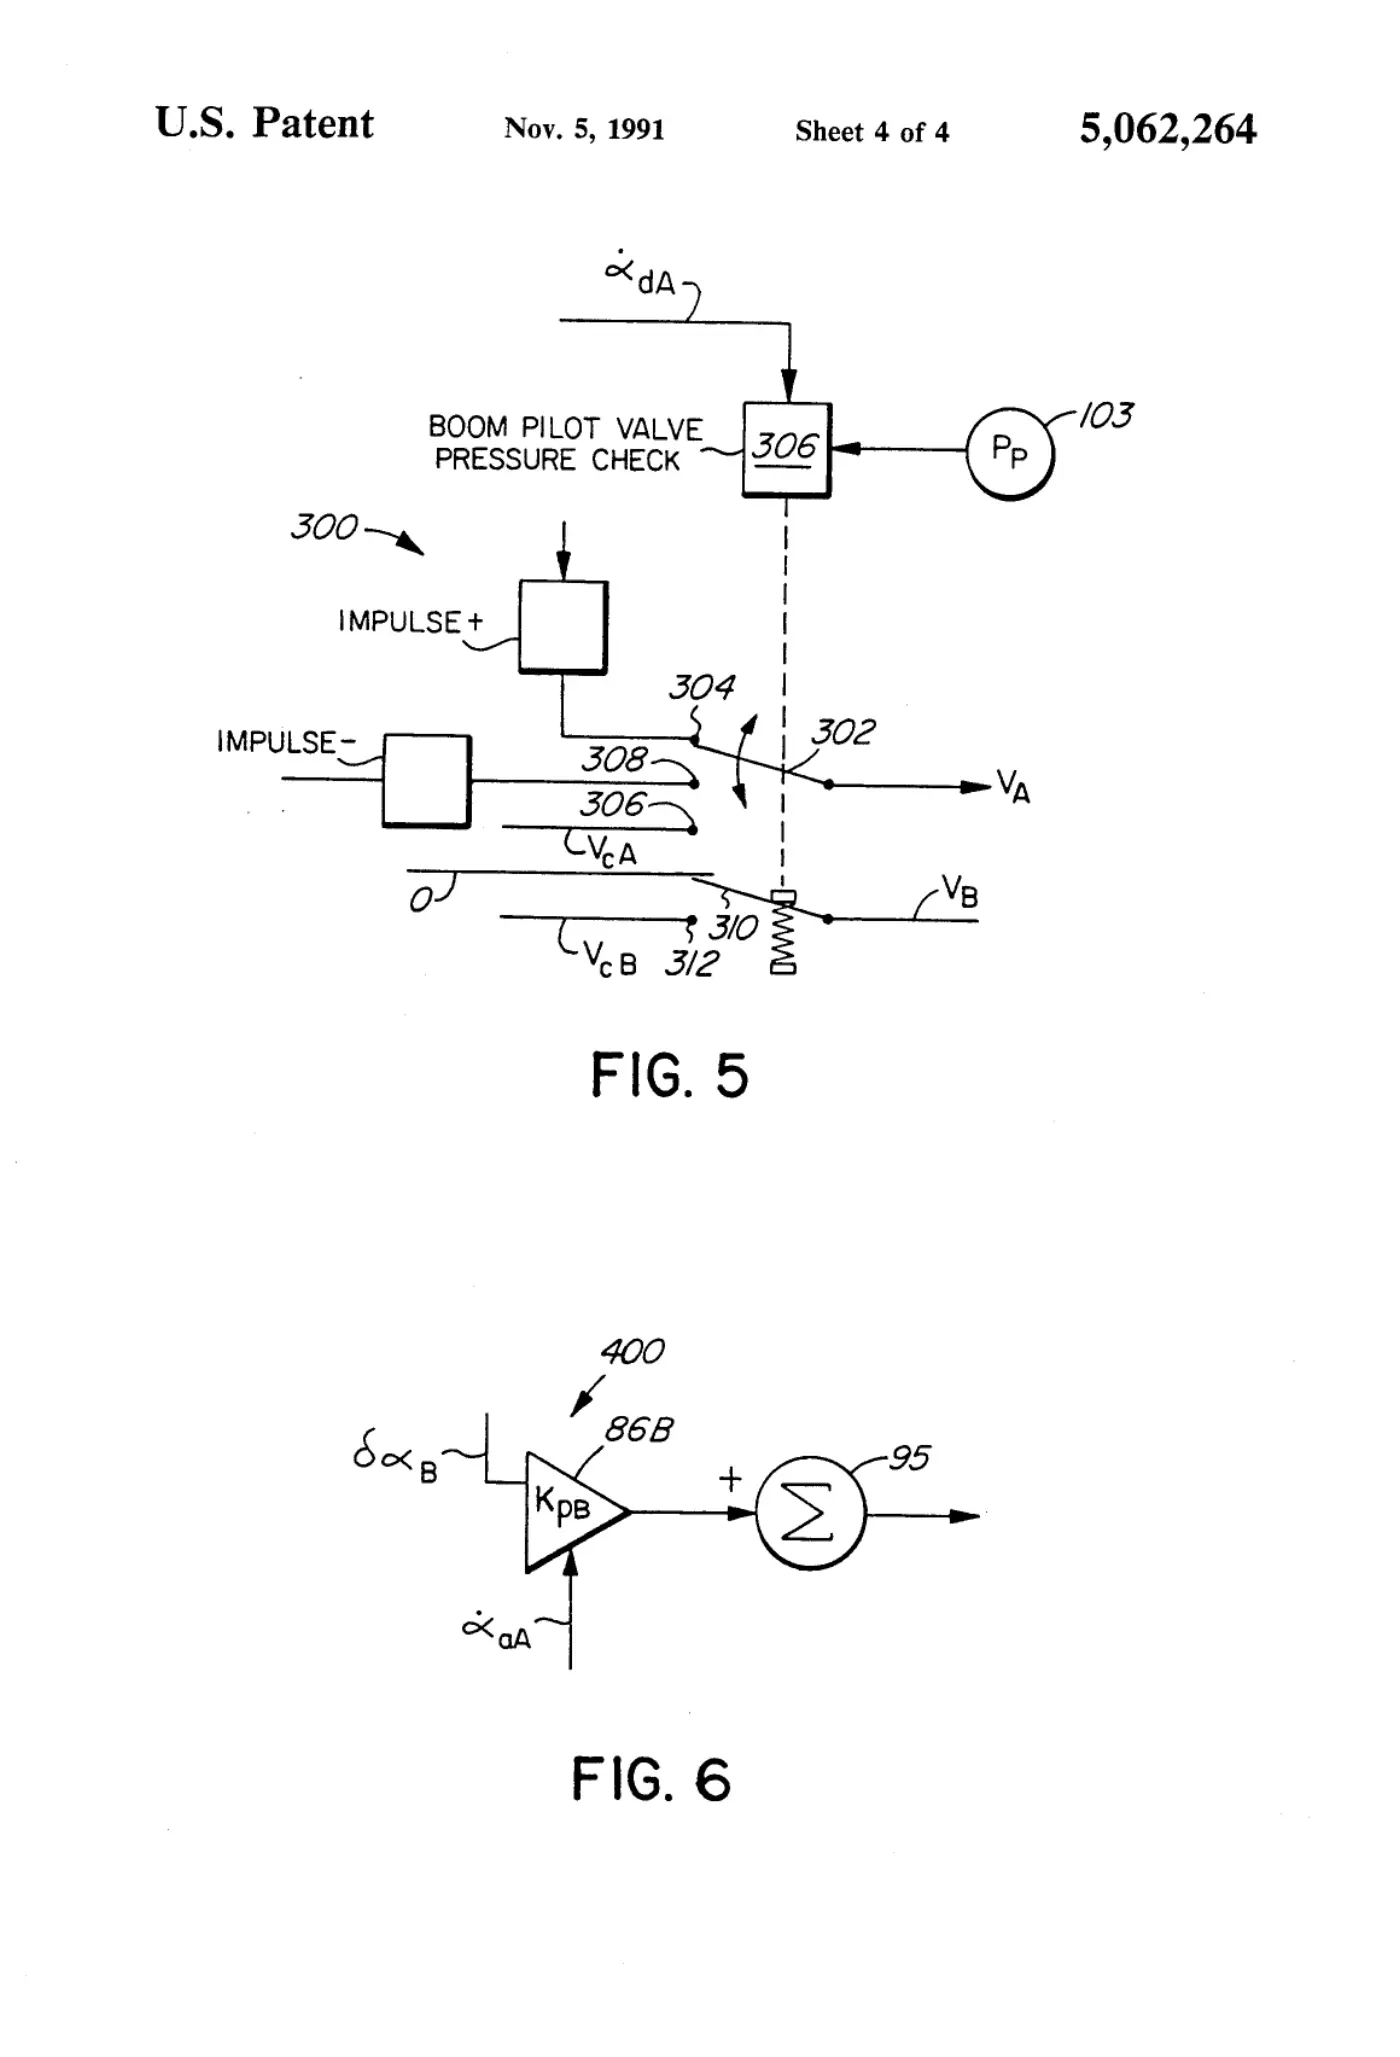
[0004]Sheet 4.
Publication information
Citation
OpenTechnical Publication OT-2026-000003413, “Hydraulic control system,” published September 15, 2026 at 20:24:44 UTC, https://opentechnical.org/p/OT-2026-000003413.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.