OT-2026-000003422
Vacuum control system for lifting systems
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003422
- Classification
- Lifting, Positioning & Manipulation › Lift Tables and Positioners
- Assignee
- MESSINGER ROBERT
- Original source
- US-5035456-A, the United States Patent and Trademark Office, 30 July 1991
- Document SHA-256
- 953aefe54b6e488f69b98edce3b37a9f140d7625275a5fee9205a3244012ae43
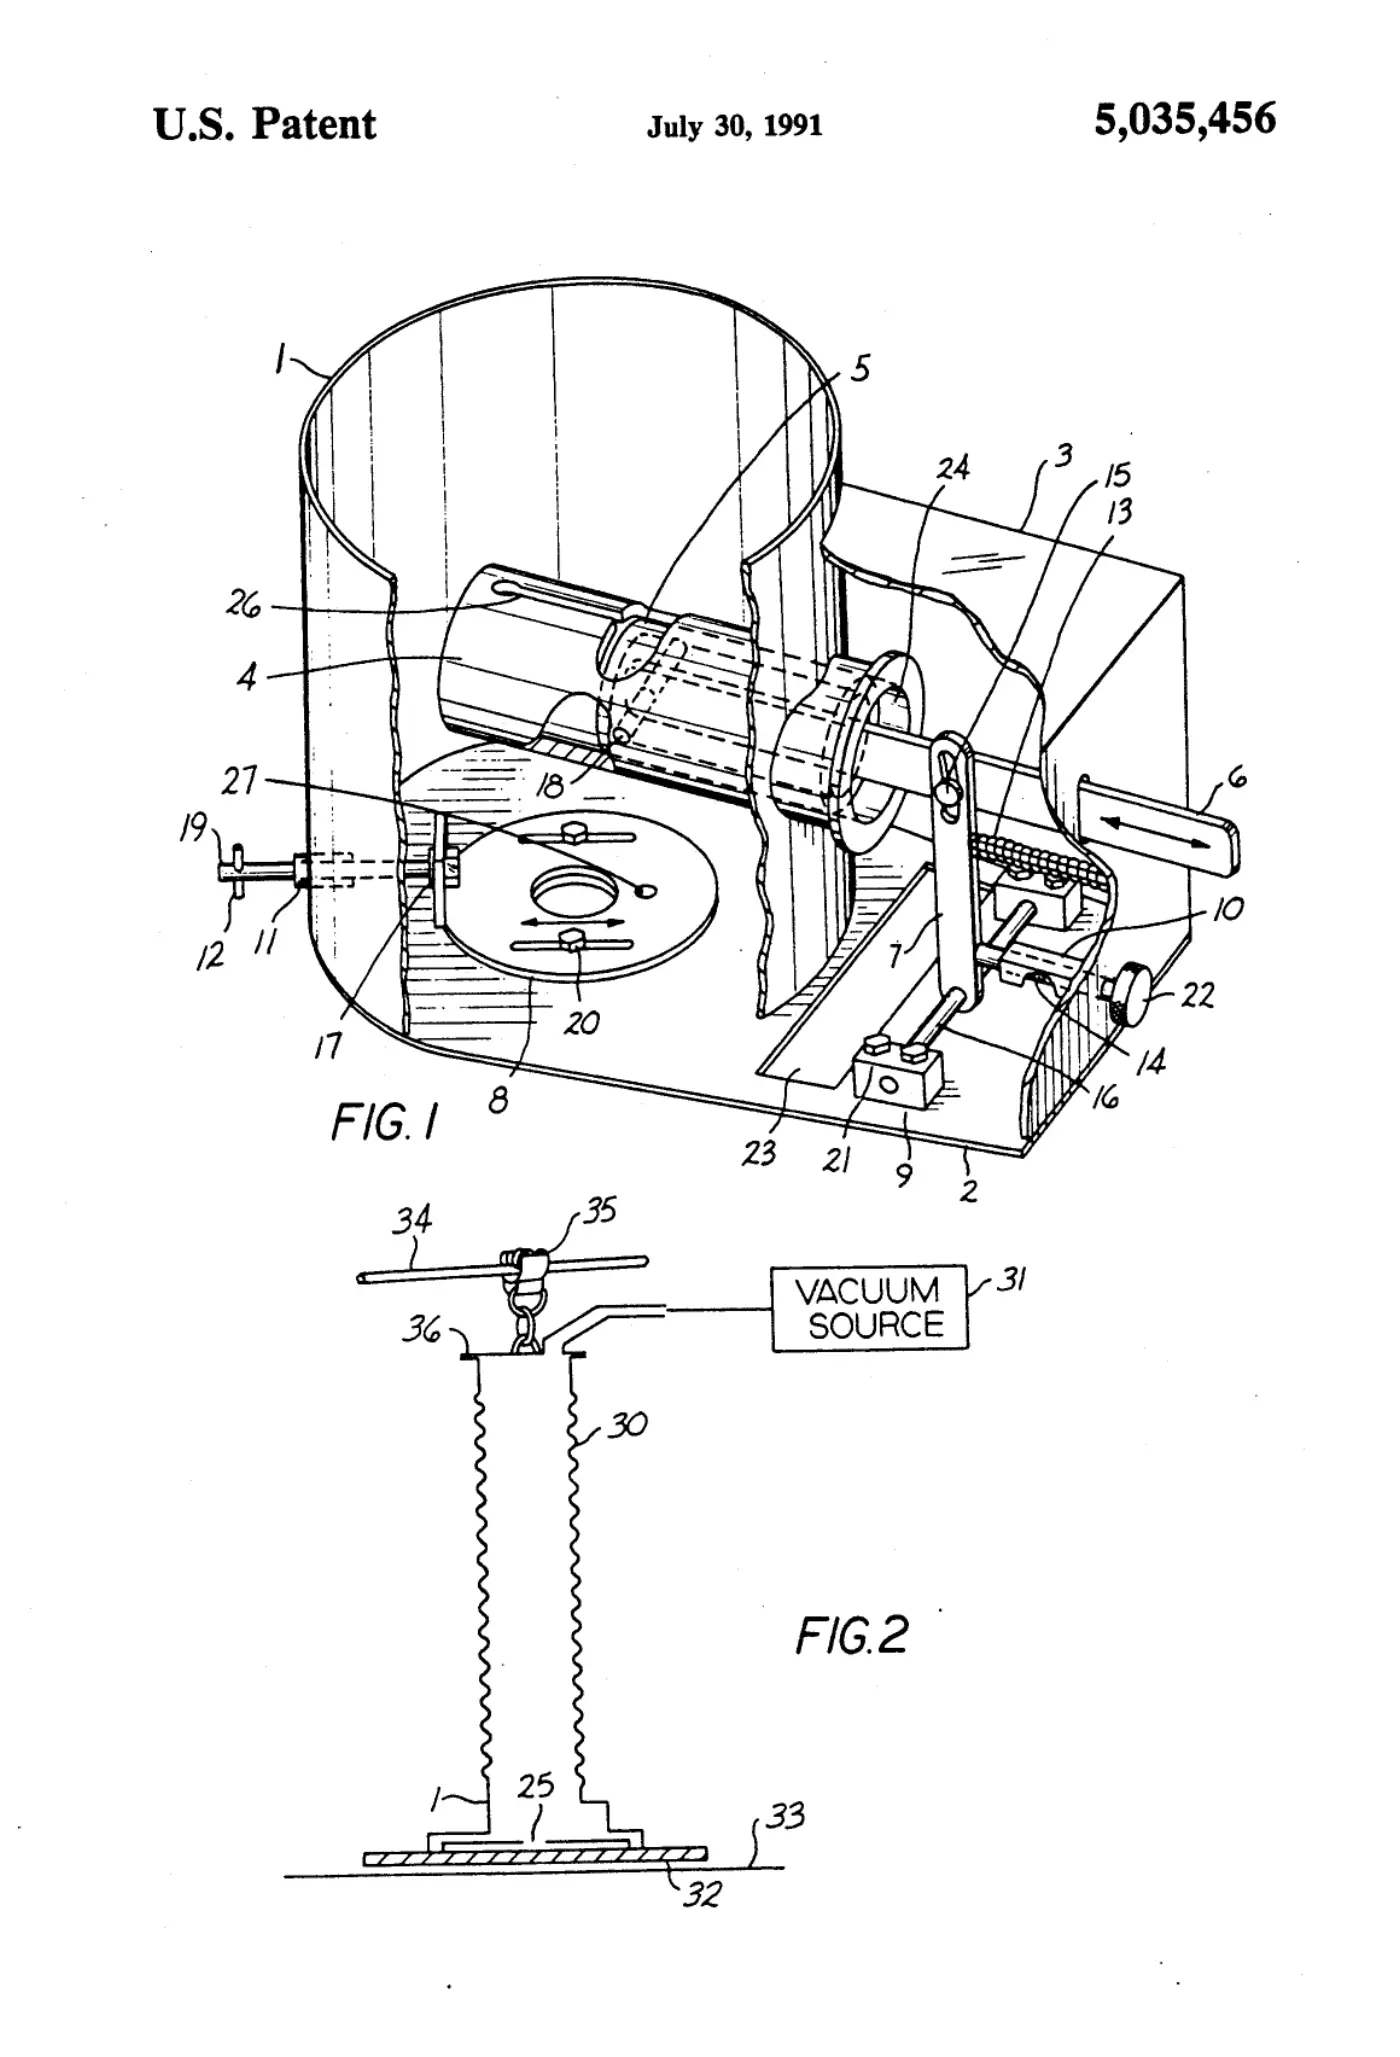
This invention provides improved body length adjustment value structure for a vacuum powered lifting system of the type that embodies a variable length lifting body responsive to the differential of pressure inside that body with atmospheric pressure to resolve critical manual control problems. Thus control is provided by proportional movement of a control member over a substantially linear range producing a smooth progressive movement of the lifting mechanism. This permits non-critical lowering and release of a work load object by unskilled operators. Thus, an air injection valve with an air release port, is positioned within the lifting body having an elongated slot operable over a control range proportionately change the body length by release of a progressively increasing flow of air into the body to increase air pressure and body length over the critical range of lowering and releasing the work load object in response to a corresponding substantially linear movement of the control member. Variable adjustment value structure establishes a known upper lift limit by control of the length of the body both under loaded and unloaded conditions, and provisions are made to keep a vacuum responsive work object grasping mechanism continuously operable.
Abstract
This invention provides improved body length adjustment value structure for a vacuum powered lifting system of the type that embodies a variable length lifting body responsive to the differential of pressure inside that body with atmospheric pressure to resolve critical manual control problems. Thus control is provided by proportional movement of a control member over a substantially linear range producing a smooth progressive movement of the lifting mechanism. This permits non-critical lowering and release of a work load object by unskilled operators. Thus, an air injection valve with an air release port, is positioned within the lifting body having an elongated slot operable over a control range proportionately change the body length by release of a progressively increasing flow of air into the body to increase air pressure and body length over the critical range of lowering and releasing the work load object in response to a corresponding substantially linear movement of the control member. Variable adjustment value structure establishes a known upper lift limit by control of the length of the body both under loaded and unloaded conditions, and provisions are made to keep a vacuum responsive work object grasping mechanism continuously operable.
1. Drawings
[0001]Sheet 1.
Publication information
Citation
OpenTechnical Publication OT-2026-000003422, “Vacuum control system for lifting systems,” published September 15, 2026 at 20:25:36 UTC, https://opentechnical.org/p/OT-2026-000003422.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.