OT-2026-000003428
Force feedback control for backhoe
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003428
- Classification
- Sensors, Controls & Machine Vision › Industrial Control
- Assignee
- KRAFT BRETT W
- Original source
- US-5019761-A, the United States Patent and Trademark Office, 28 May 1991
- Document SHA-256
- ffcd5ed419d480f0f14bacb245dc97da554f018fe1ae334251b14f0b8f4d99ed
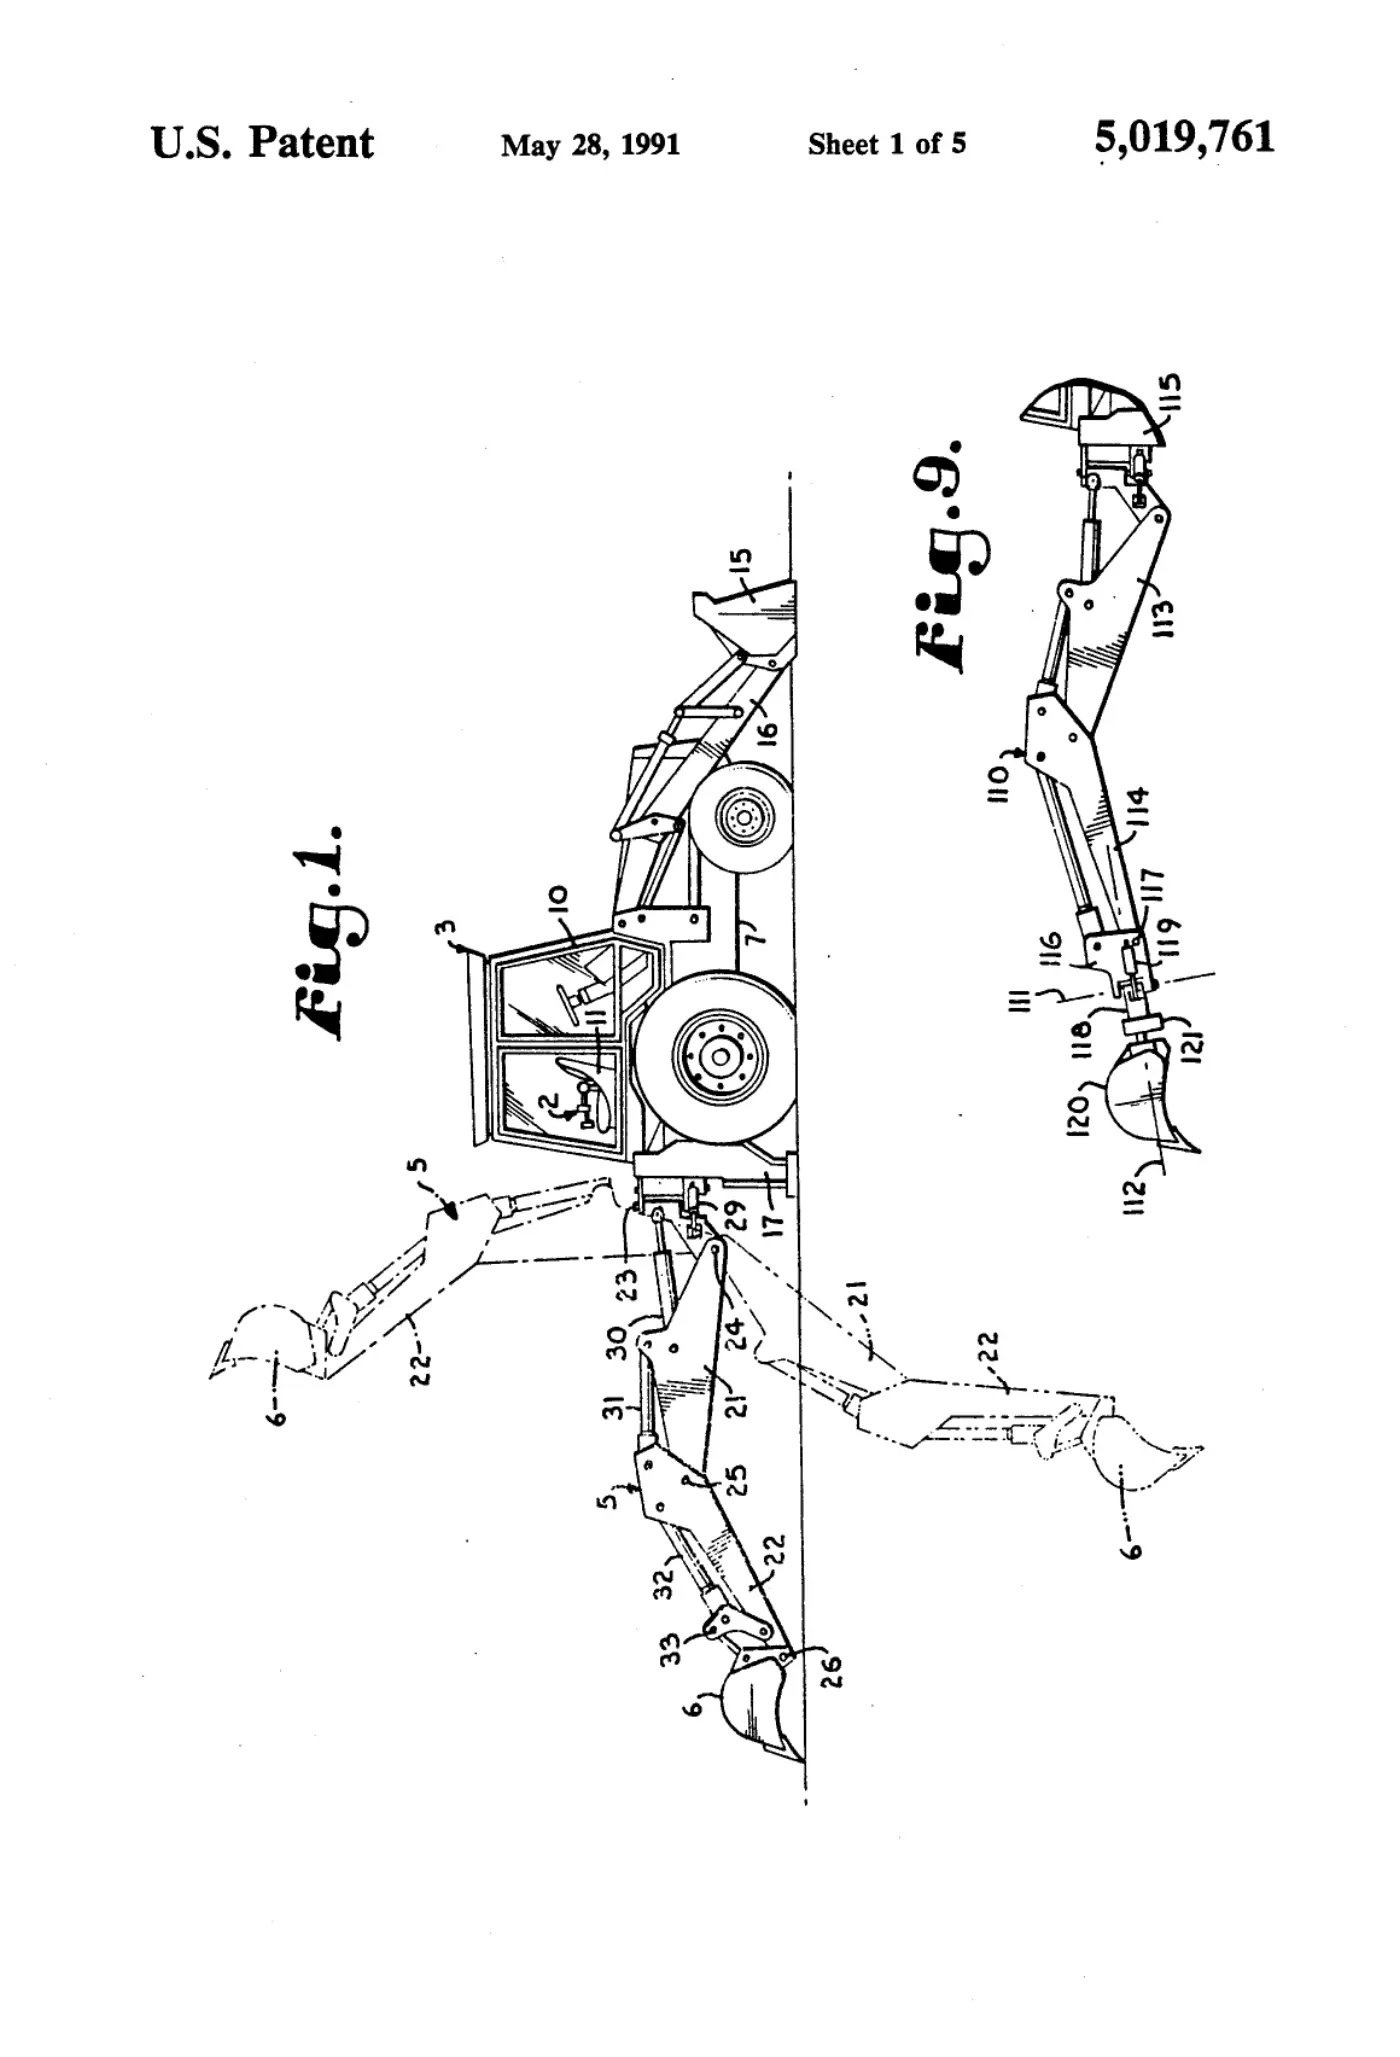
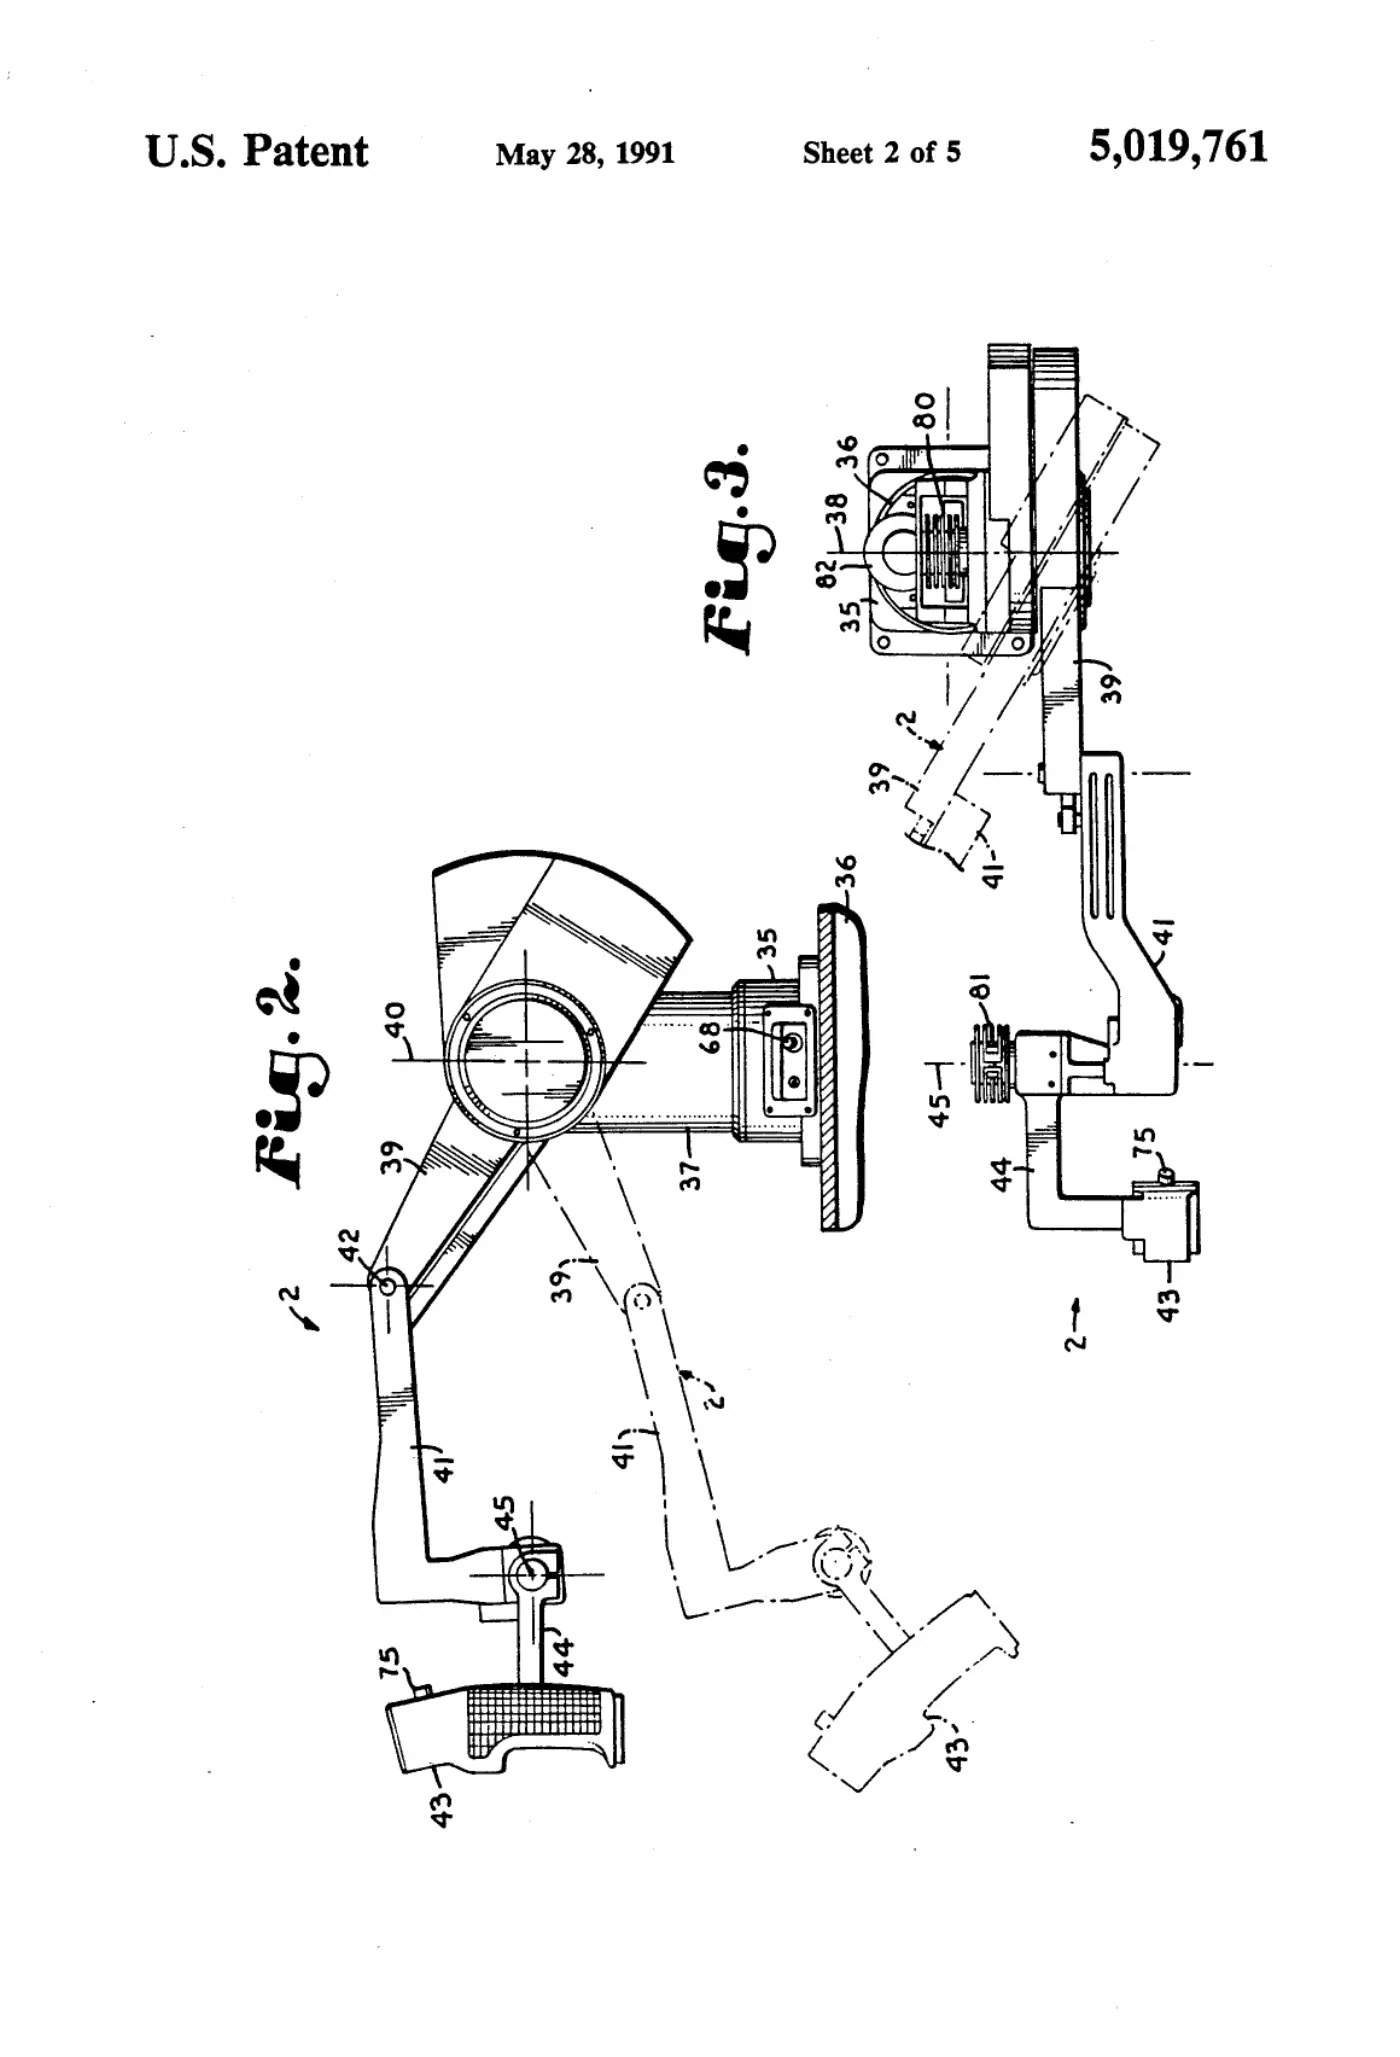
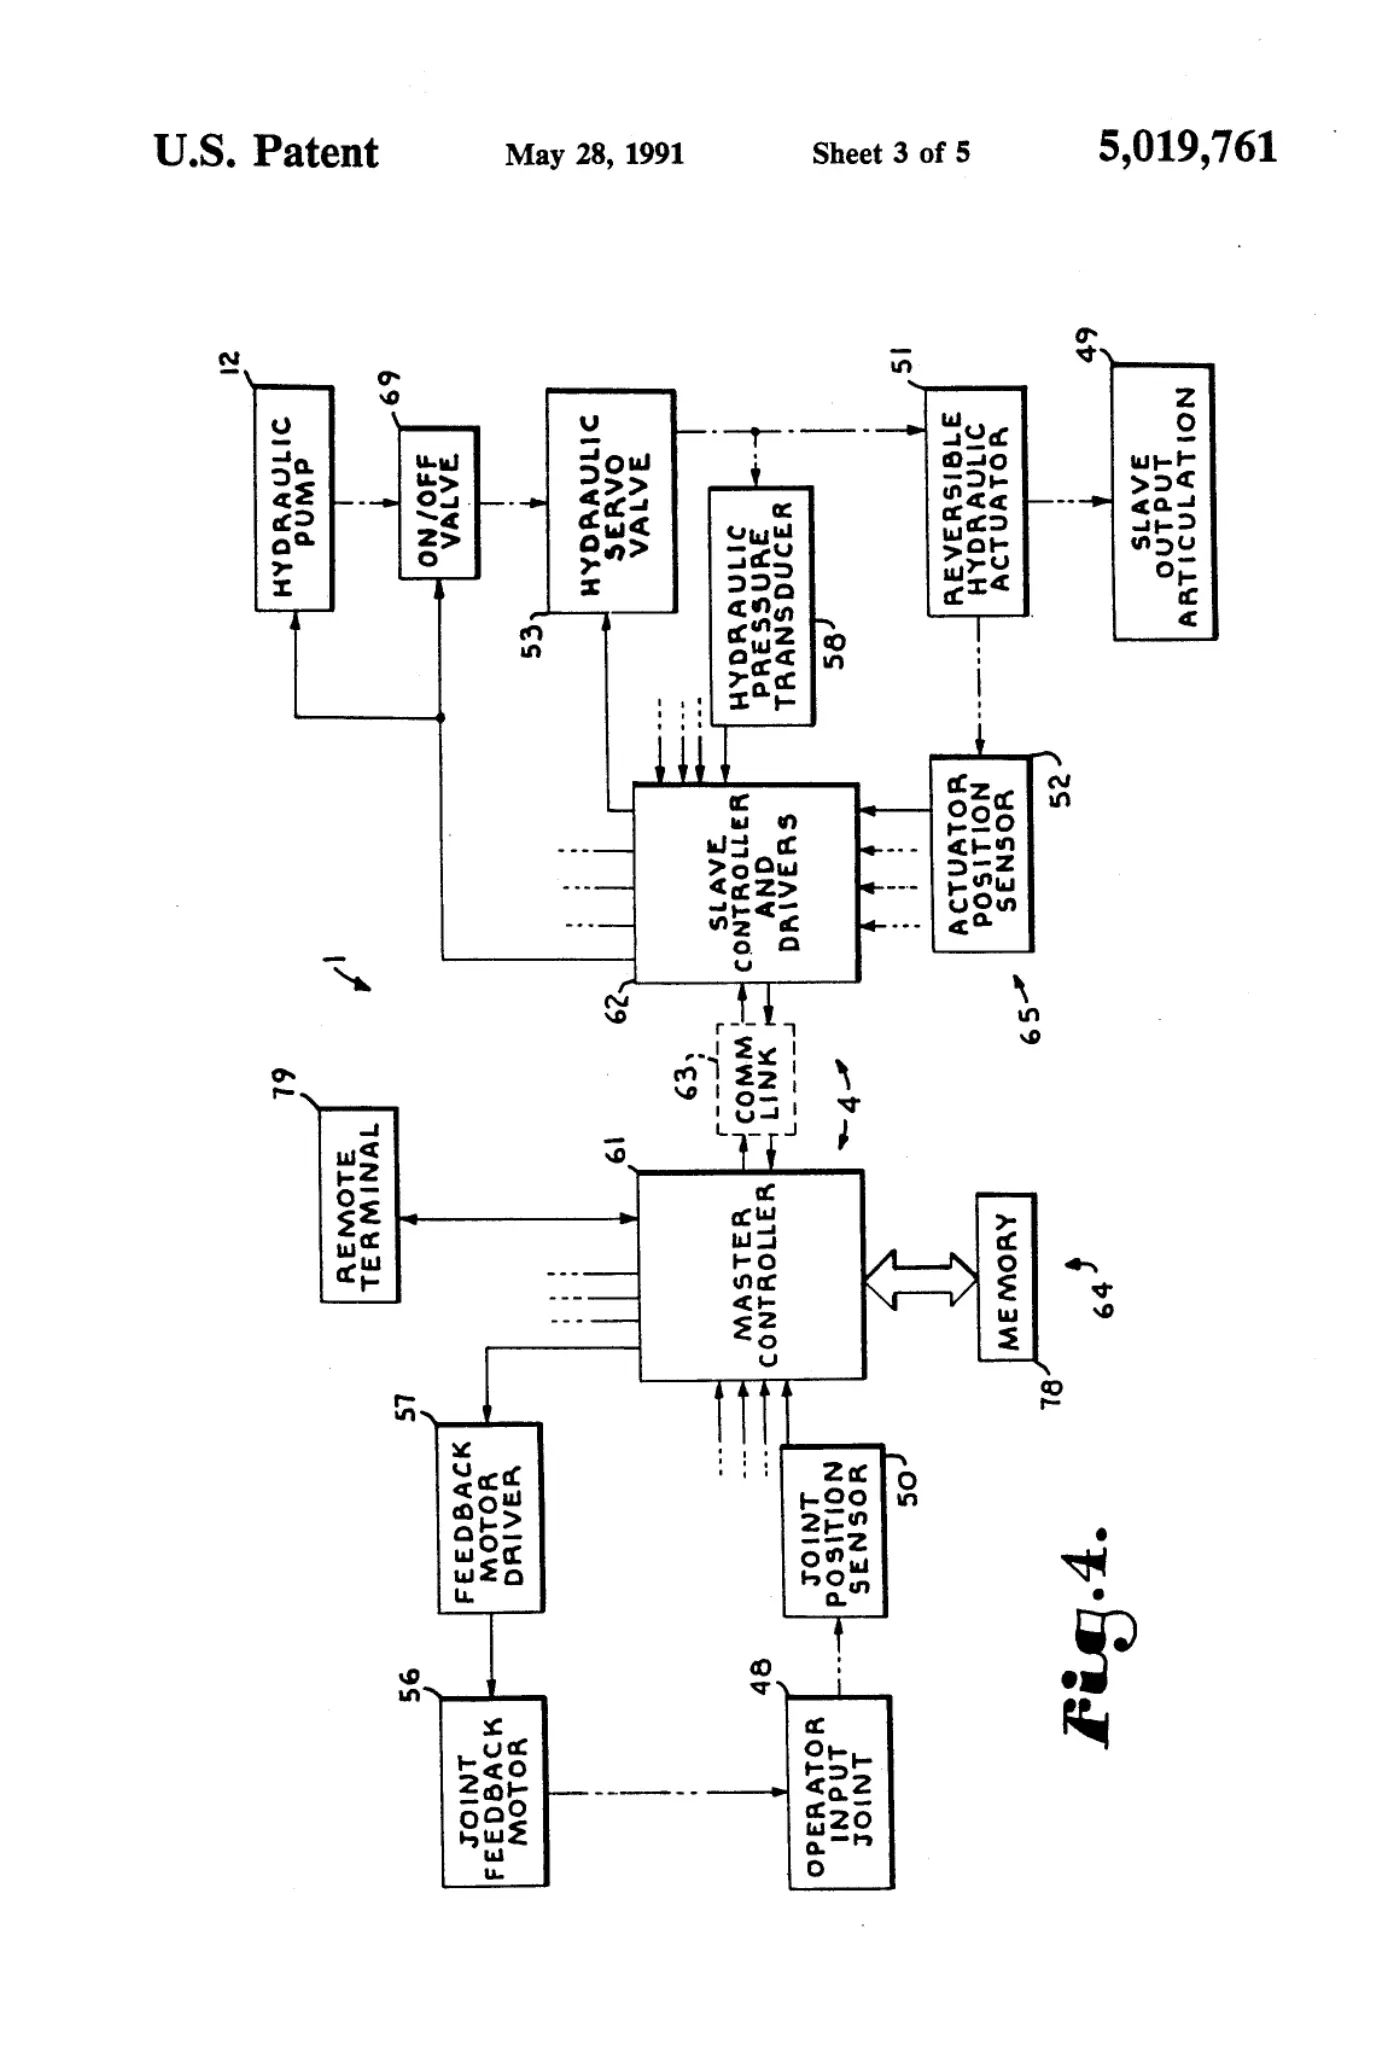
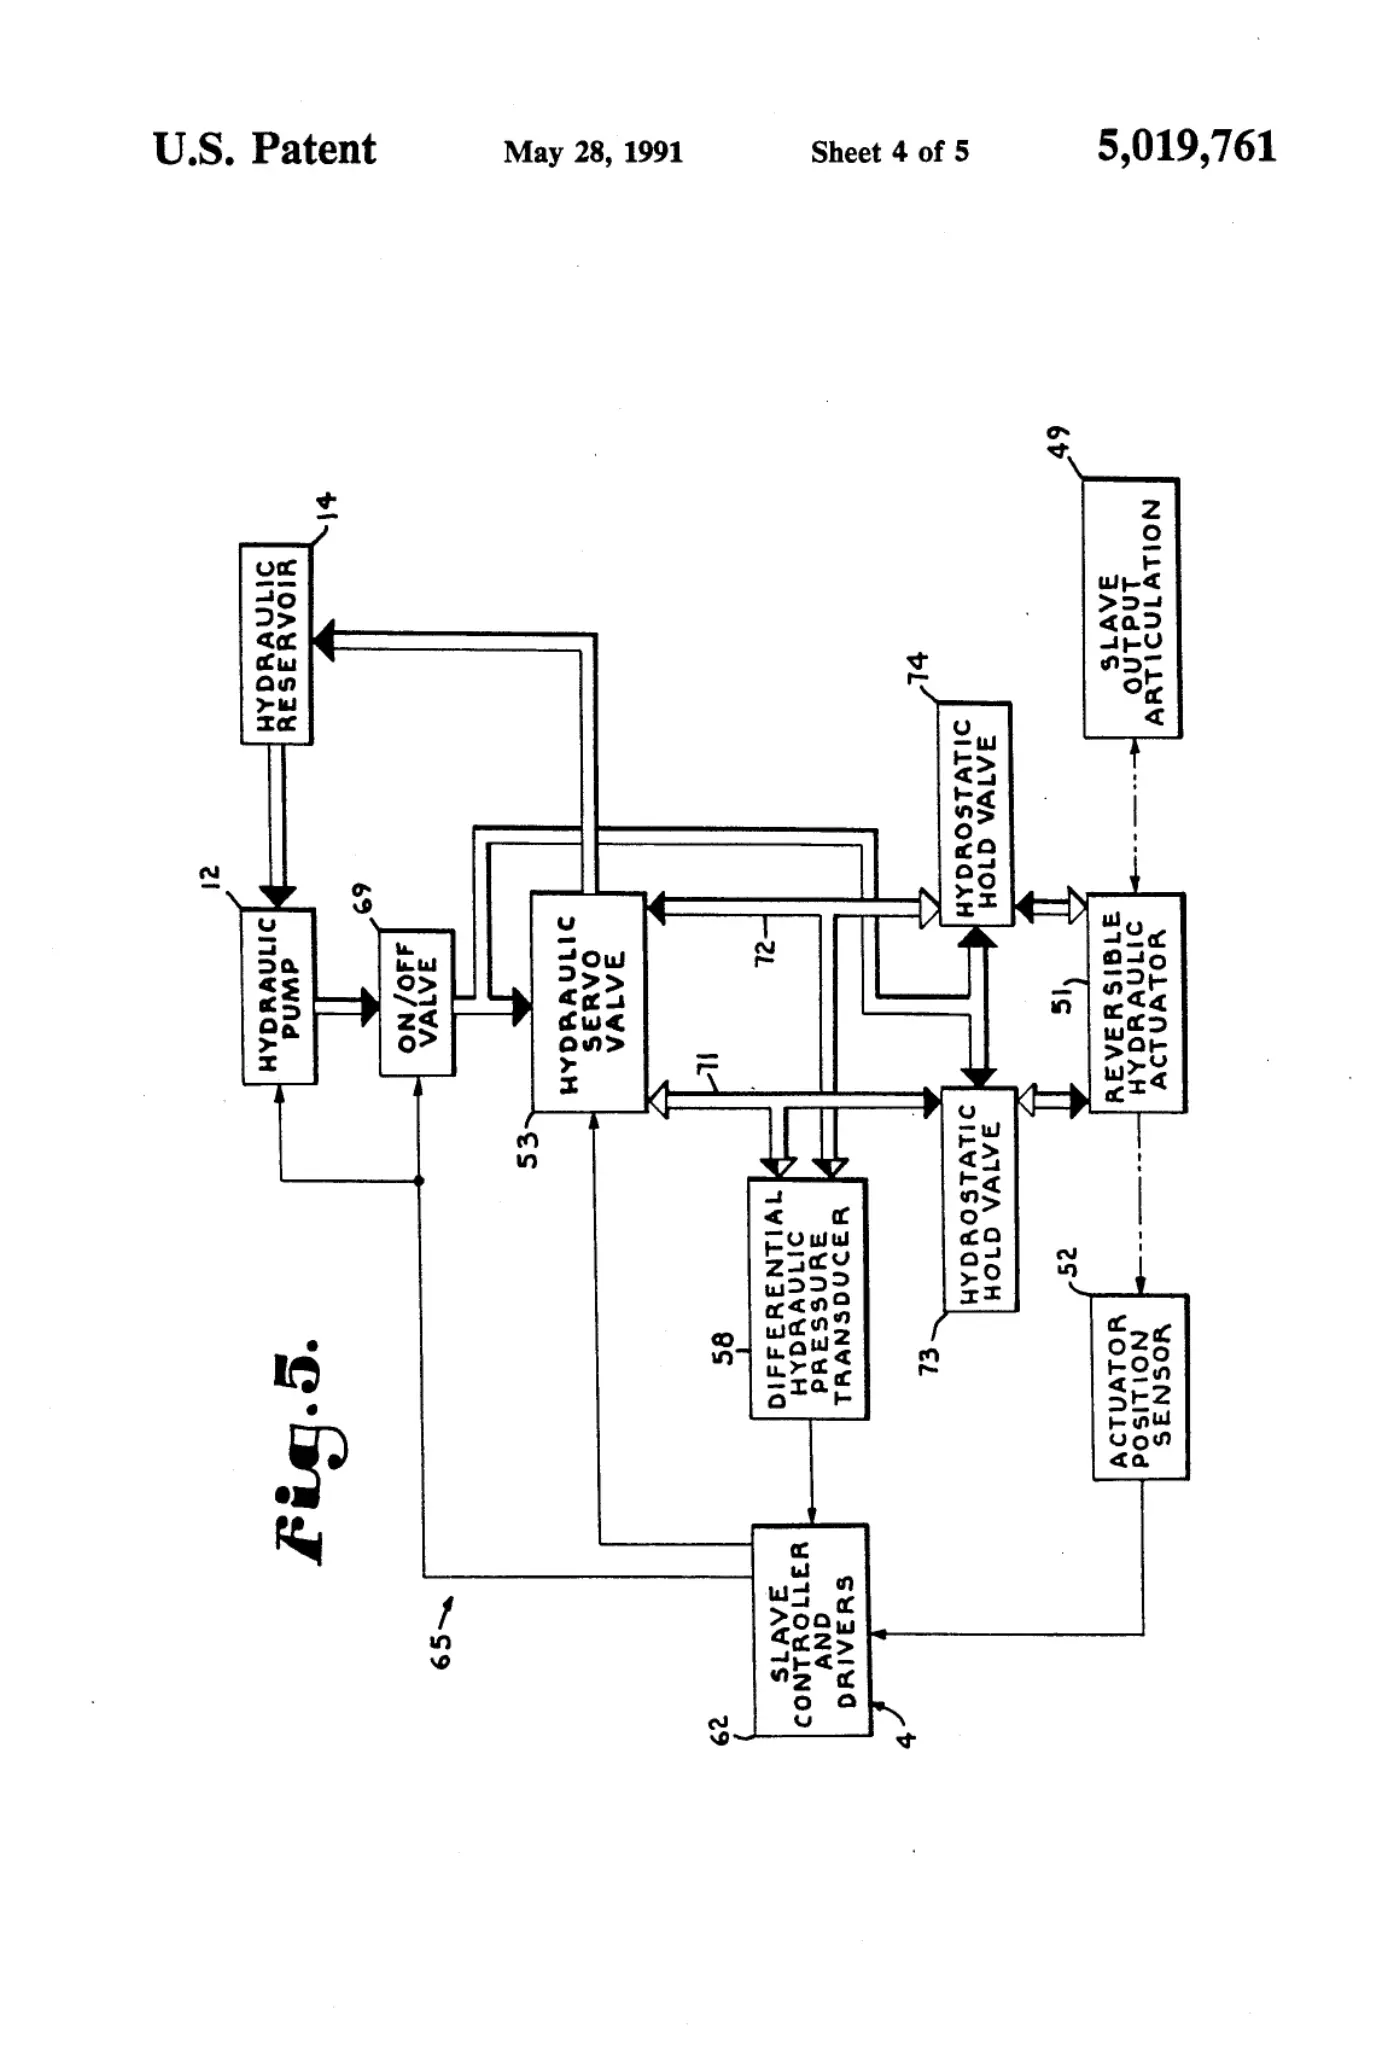
A force feedback control system for a backhoe includes a single grip articulated control arm having members and joints therebetween analogous to the members and joints of an articulated backhoe arm connecting an excavation bucket to a backhoe frame. A bilateral closed loop control circuit compares slave position signals from output joint position sensors associated with the backhoe arm joints with corresponding master position signals from input joint sensors associated with the control arm joints and provides command signals to actuators associated with the backhoe joints to move them so that differences in corresponding master and slave position signals are minimized. Backhoe joint load sensors provide load signals indicating resistance to movement of the associated backhoe joints, and the control circuit generates force feedback signals to drive feedback motors associated with the control arm joints to apply toruqes thereto to reflect the resistance to movement of the associated backhoe joints.
Abstract
A force feedback control system for a backhoe includes a single grip articulated control arm having members and joints therebetween analogous to the members and joints of an articulated backhoe arm connecting an excavation bucket to a backhoe frame. A bilateral closed loop control circuit compares slave position signals from output joint position sensors associated with the backhoe arm joints with corresponding master position signals from input joint sensors associated with the control arm joints and provides command signals to actuators associated with the backhoe joints to move them so that differences in corresponding master and slave position signals are minimized. Backhoe joint load sensors provide load signals indicating resistance to movement of the associated backhoe joints, and the control circuit generates force feedback signals to drive feedback motors associated with the control arm joints to apply toruqes thereto to reflect the resistance to movement of the associated backhoe joints.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
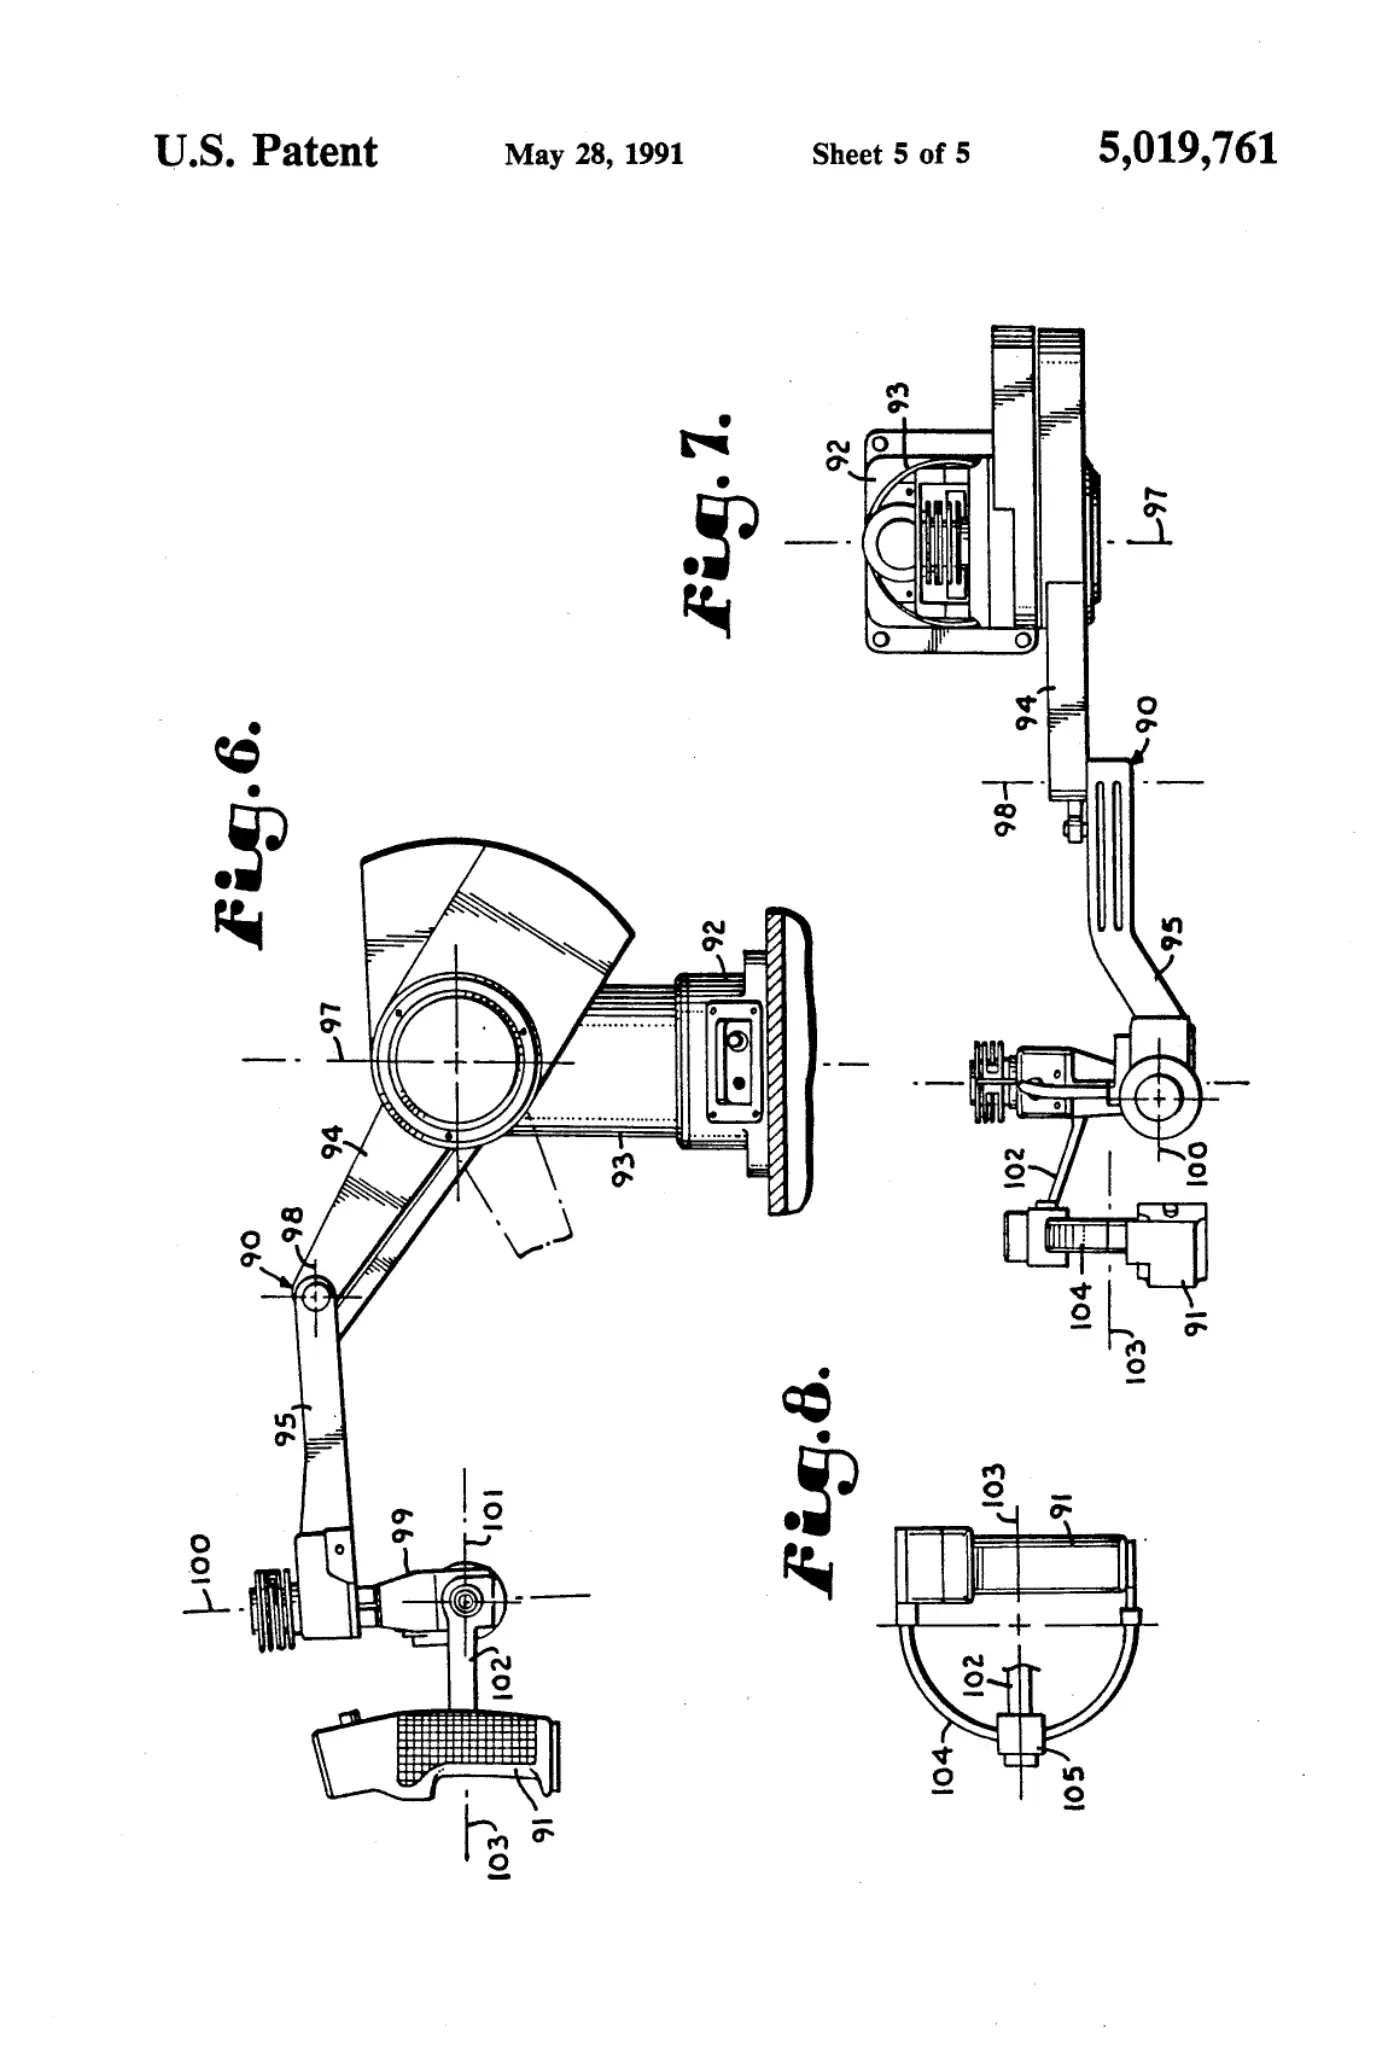
[0005]Sheet 5.
Publication information
Citation
OpenTechnical Publication OT-2026-000003428, “Force feedback control for backhoe,” published September 15, 2026 at 20:26:16 UTC, https://opentechnical.org/p/OT-2026-000003428.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.