OT-2026-000003434
System for compensated motion of coupled robot axes
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003434
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- LINTNER DAVID E, STEINMETZ MICHAEL A
- Assignee
- CINCINNATI MILACRON INC
- Original source
- US-4986724-A, the United States Patent and Trademark Office, 22 January 1991
- Document SHA-256
- 835961023953793756daa9fc53b0db8ae2b9bce87f4d472b84ab2424ac09a436
A system for accurately and smoothly moving the tool centerpoint of a manipulator device. The system includes means for measuring the angles at the elbow pivot joint and shoulder pivot joint of the manipulator device. Required compensating movement in a second axis of the manipulator linkage as a result of movement in a first axis thereof is anticipated by the control system to enable substantially simultaneous movement of both axes, and feedback of the angular position of the pivot joints during such movements enables enhancement of the precision of the tool centerpoint movement.
Abstract
A system for accurately and smoothly moving the tool centerpoint of a manipulator device. The system includes means for measuring the angles at the elbow pivot joint and shoulder pivot joint of the manipulator device. Required compensating movement in a second axis of the manipulator linkage as a result of movement in a first axis thereof is anticipated by the control system to enable substantially simultaneous movement of both axes, and feedback of the angular position of the pivot joints during such movements enables enhancement of the precision of the tool centerpoint movement.
1. Drawings
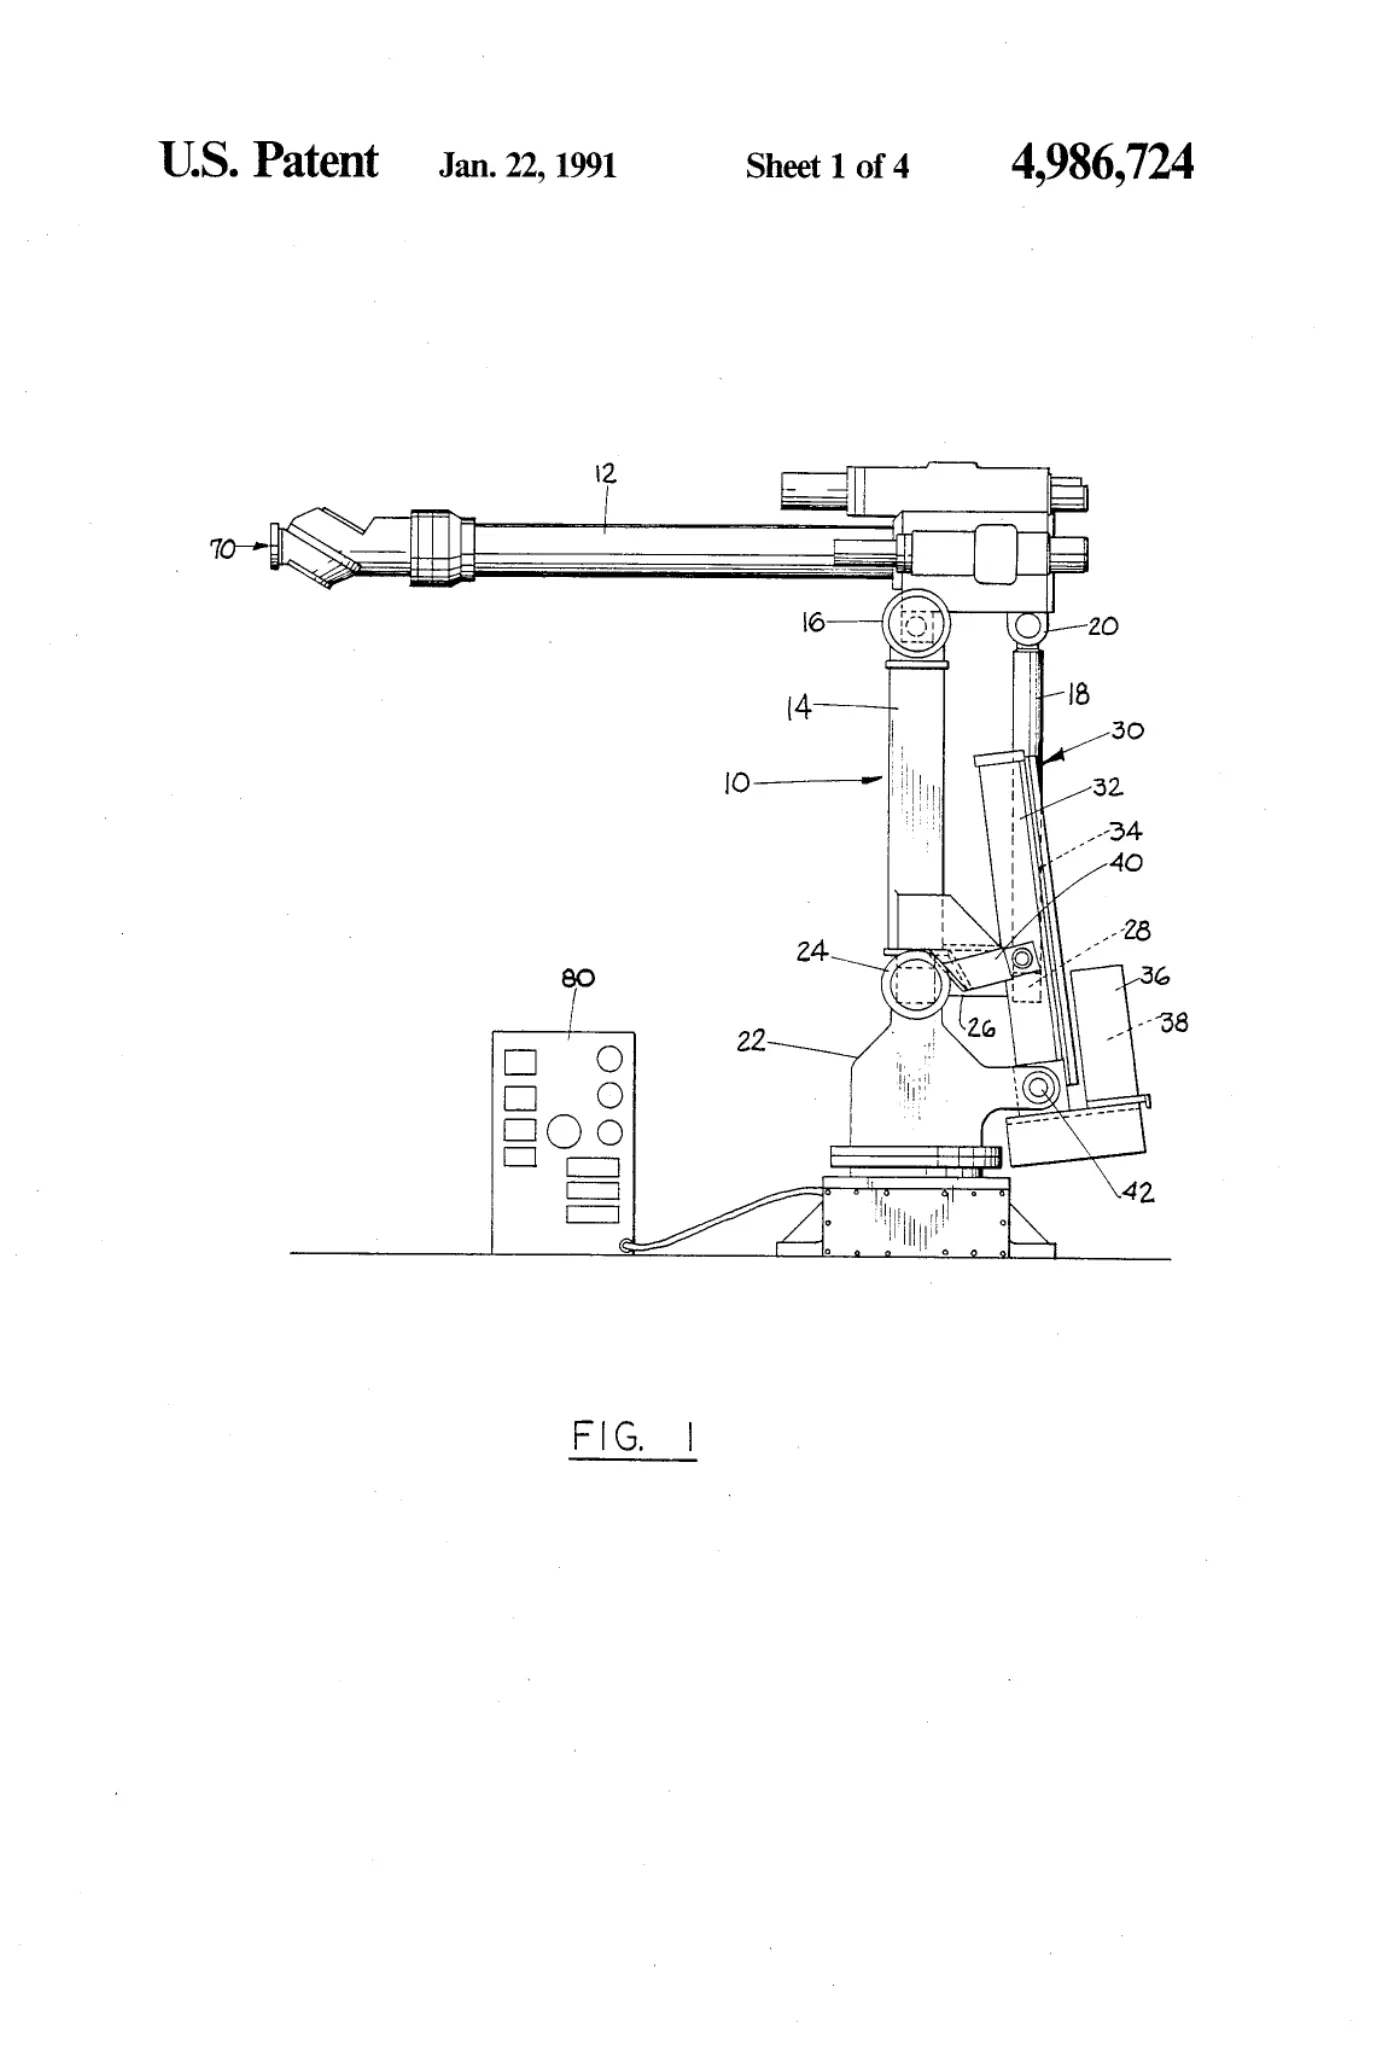
[0001]Sheet 1.
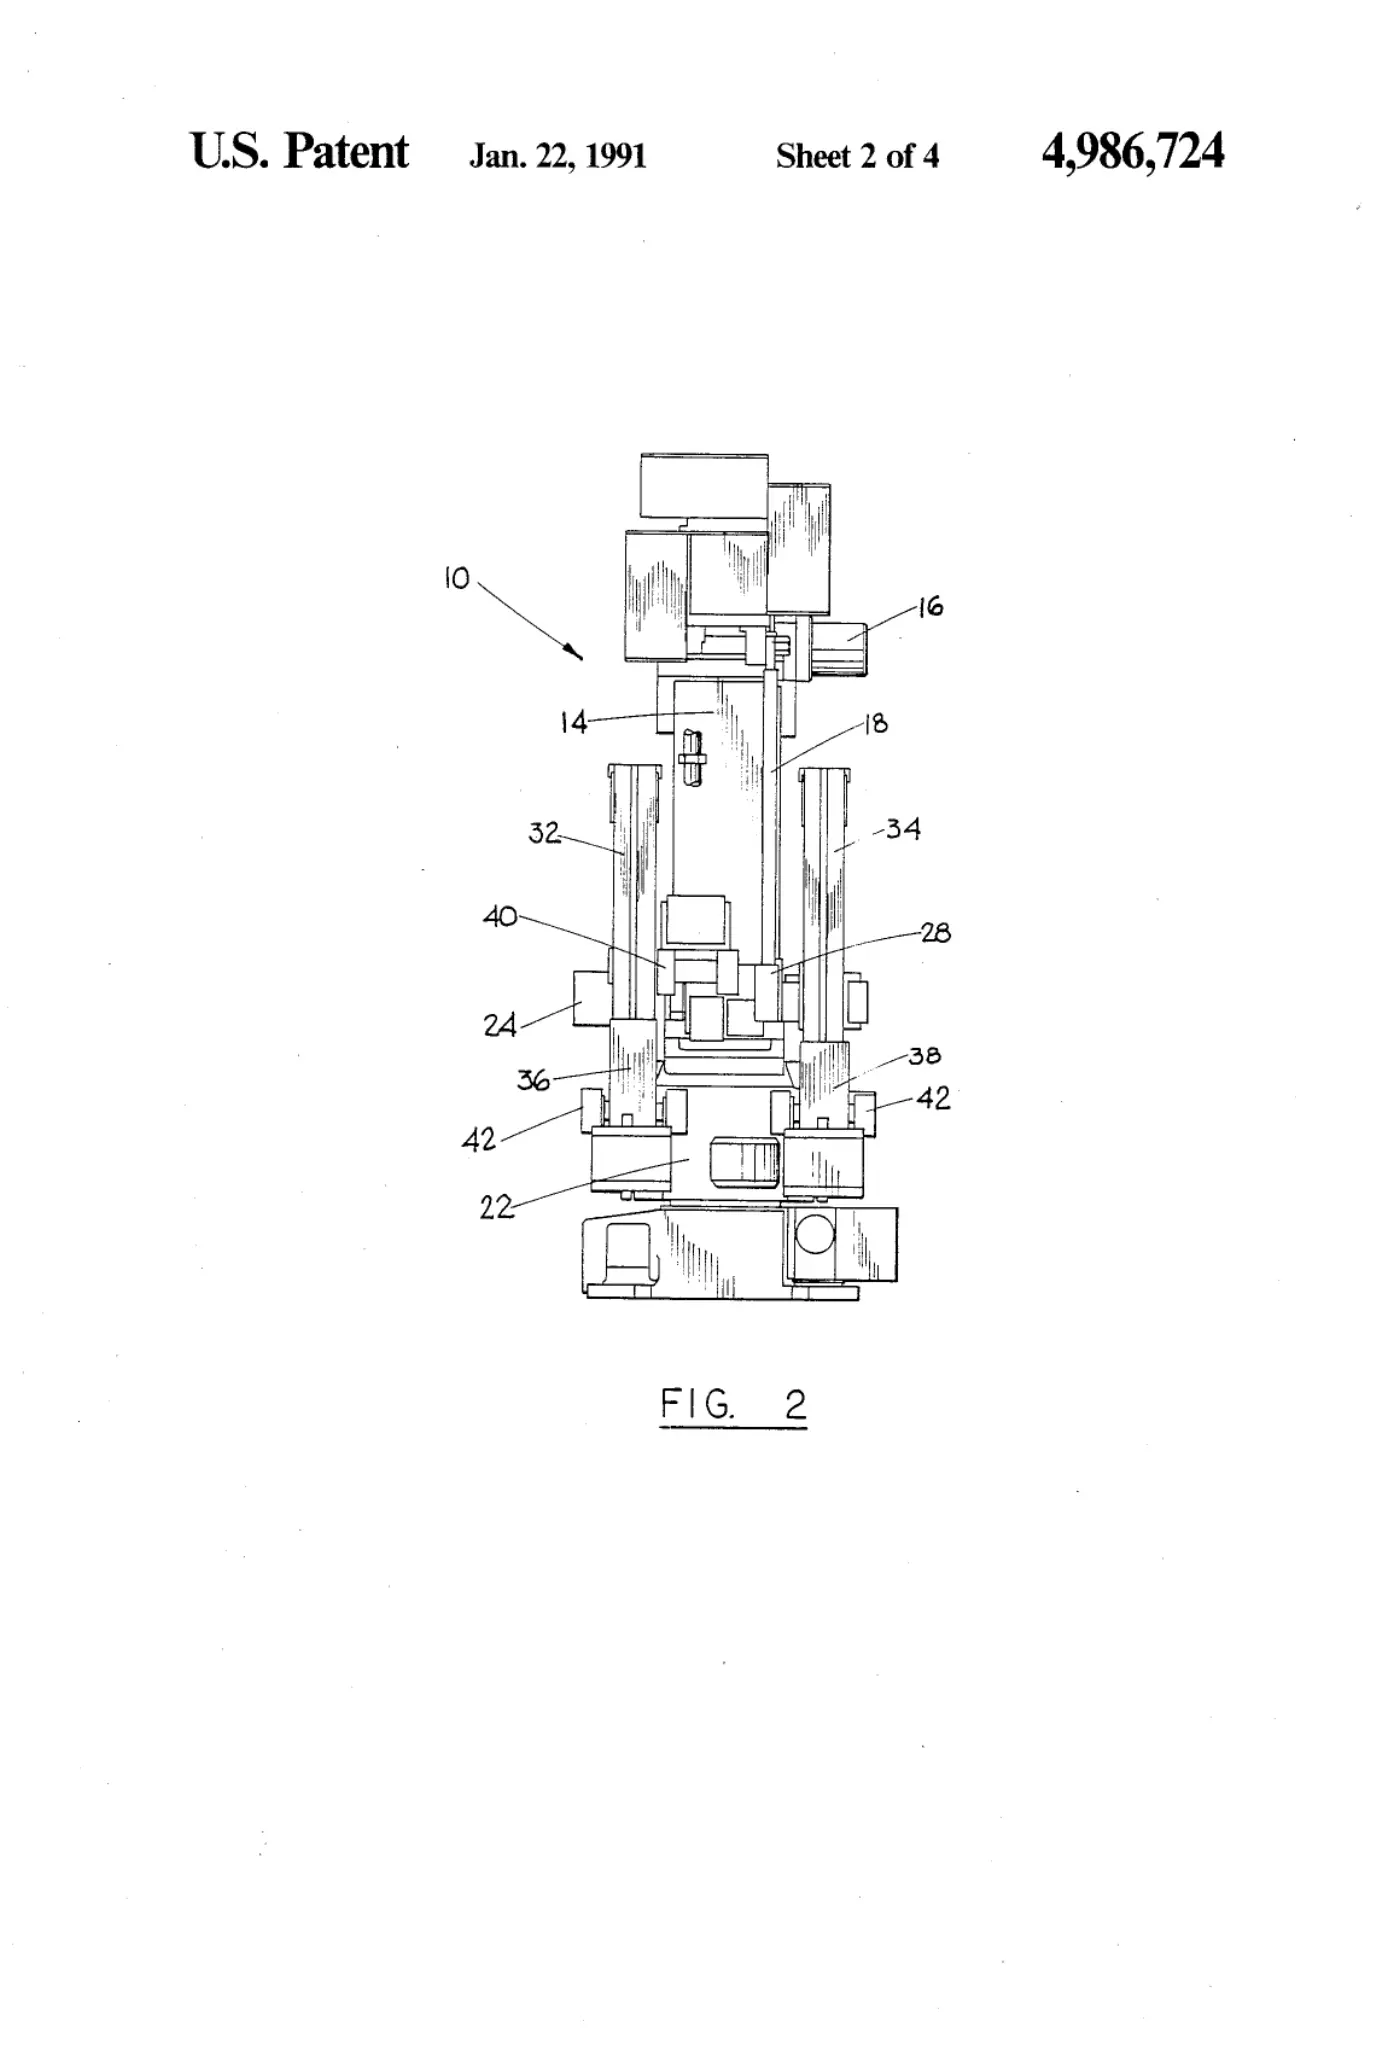
[0002]Sheet 2.
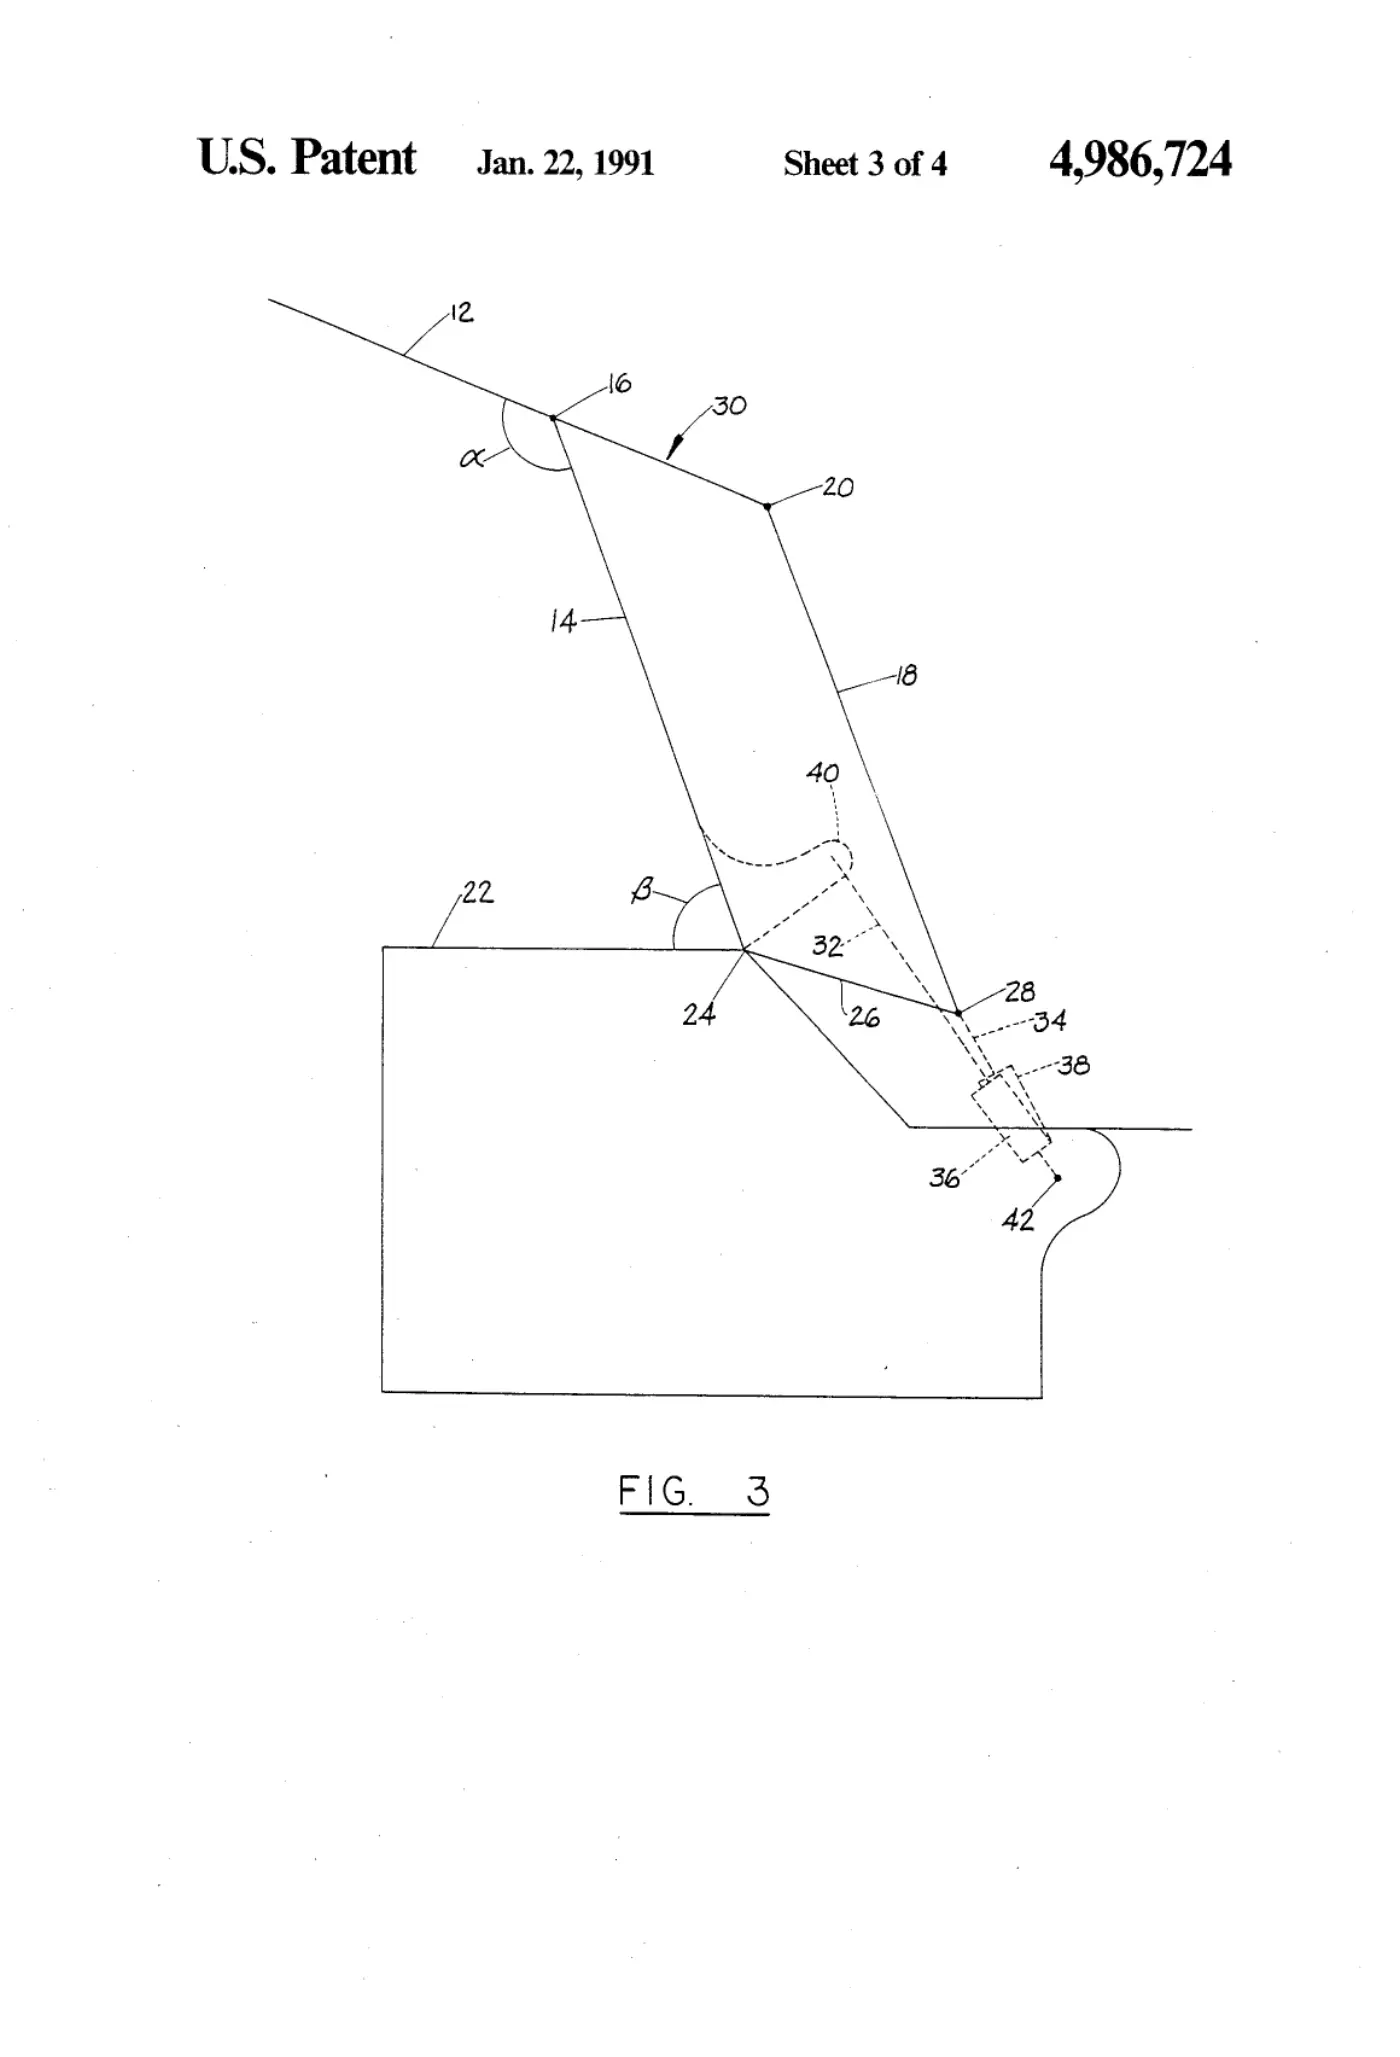
[0003]Sheet 3.
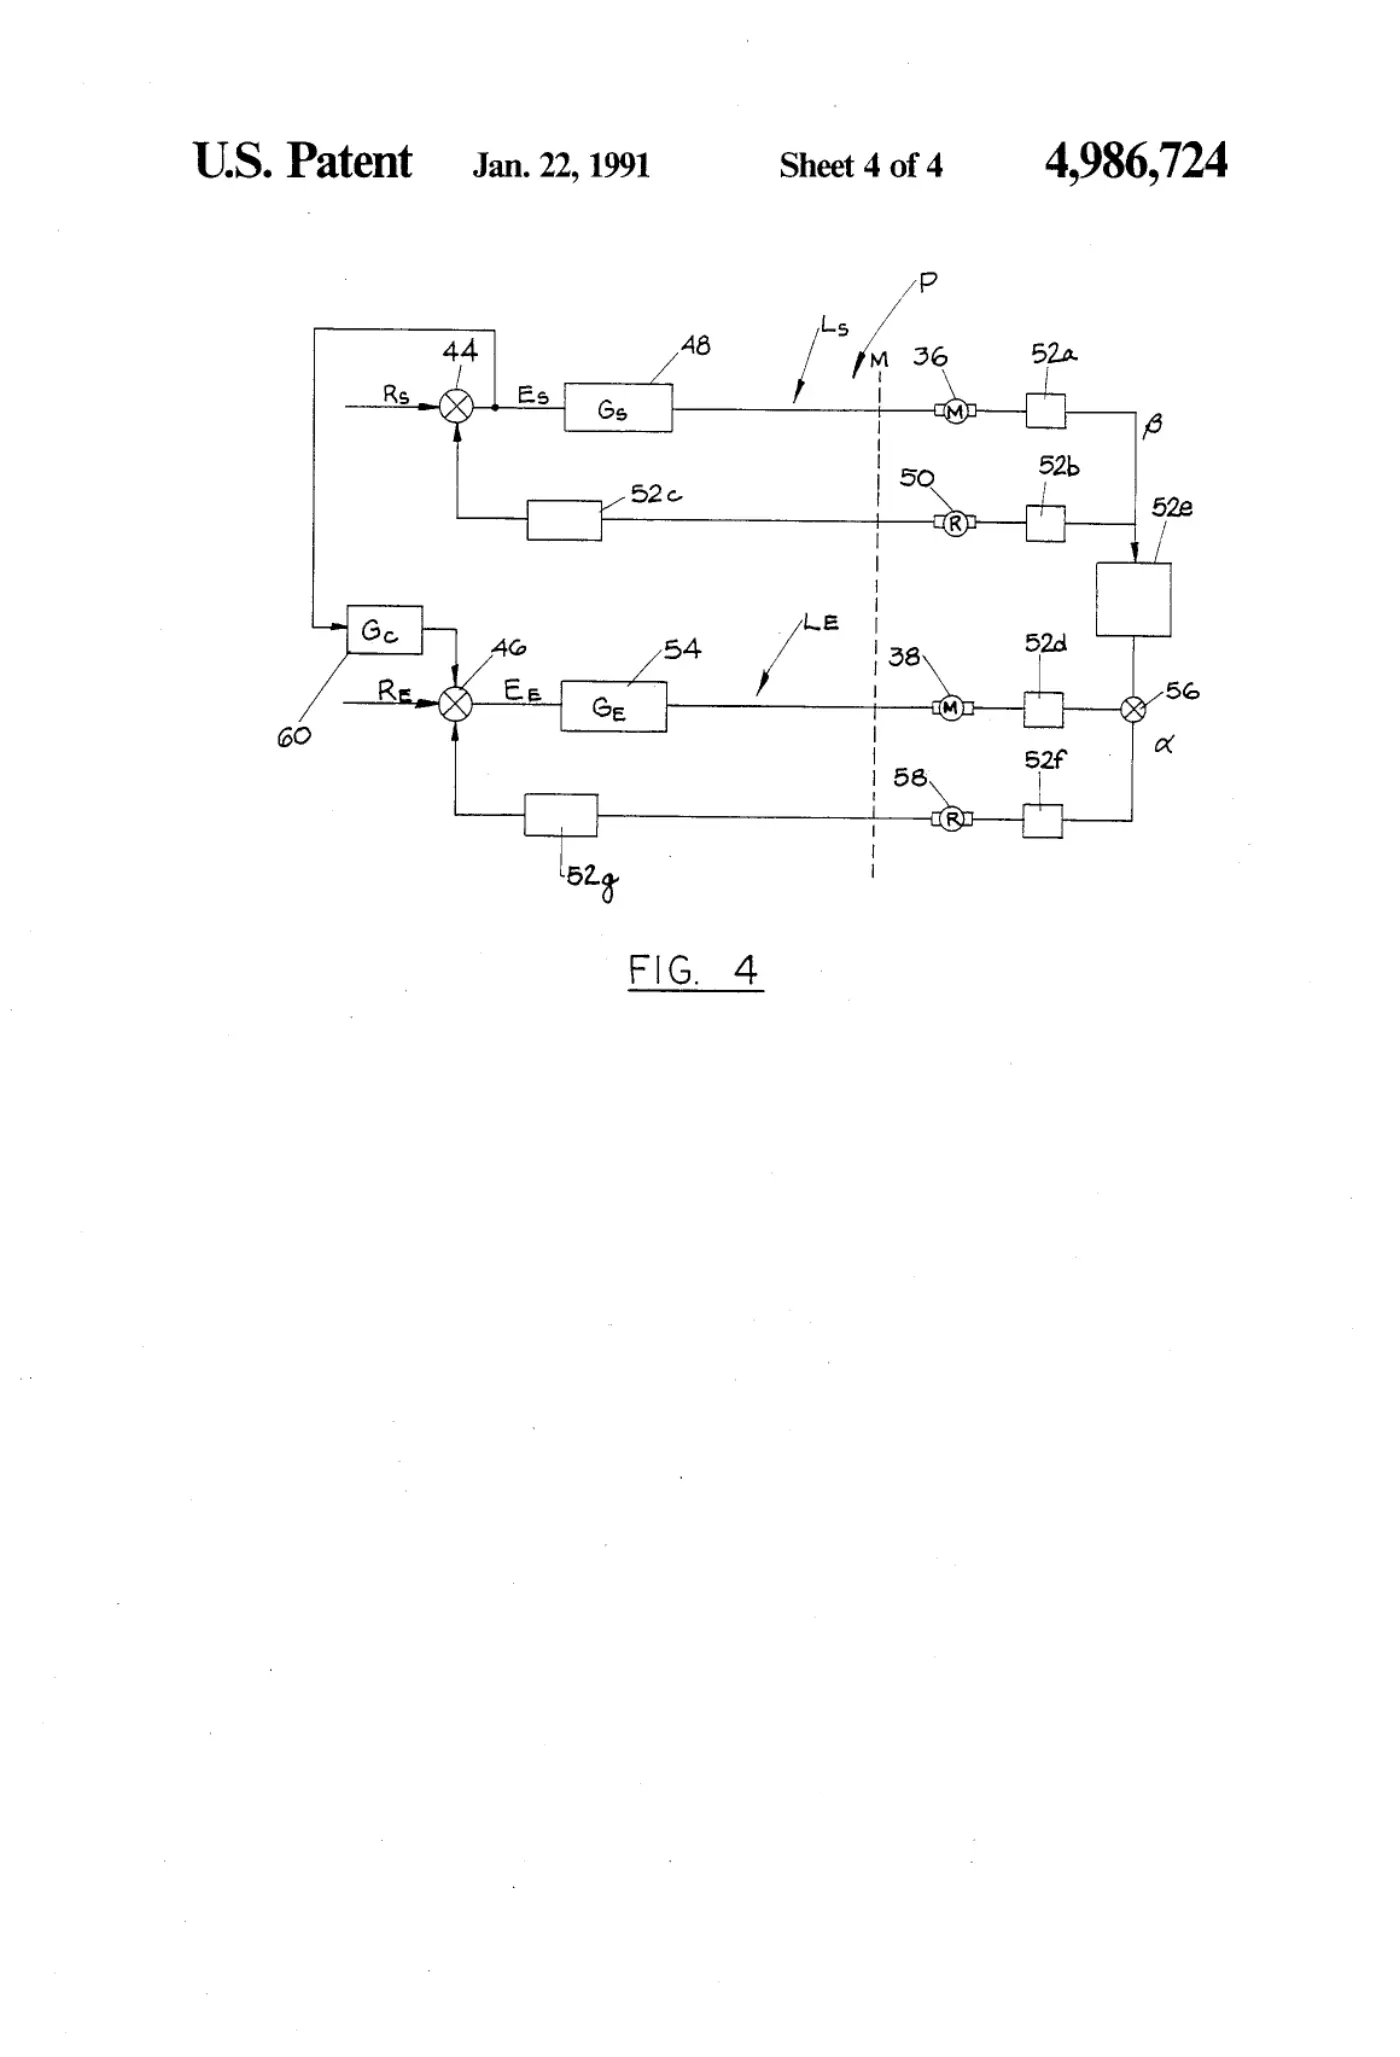
[0004]Sheet 4.
[0005]Sheet 5.
Publication information
Citation
OpenTechnical Publication OT-2026-000003434, “System for compensated motion of coupled robot axes,” published September 15, 2026 at 20:27:04 UTC, https://opentechnical.org/p/OT-2026-000003434.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.