OT-2026-000003464
Robotically controlled component feed mechanism visually monitoring part orientation
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003464
- Classification
- Robotics & Automation › Robot Architectures
- Assignee
- WESTERN TECHNOLOGIES AUTOMATIO
- Original source
- US-4909376-A, the United States Patent and Trademark Office, 20 March 1990
- Document SHA-256
- 5b1ad4e46ff9d64eb9baae70e9dc25a6143befc668bdb83126832459692df541
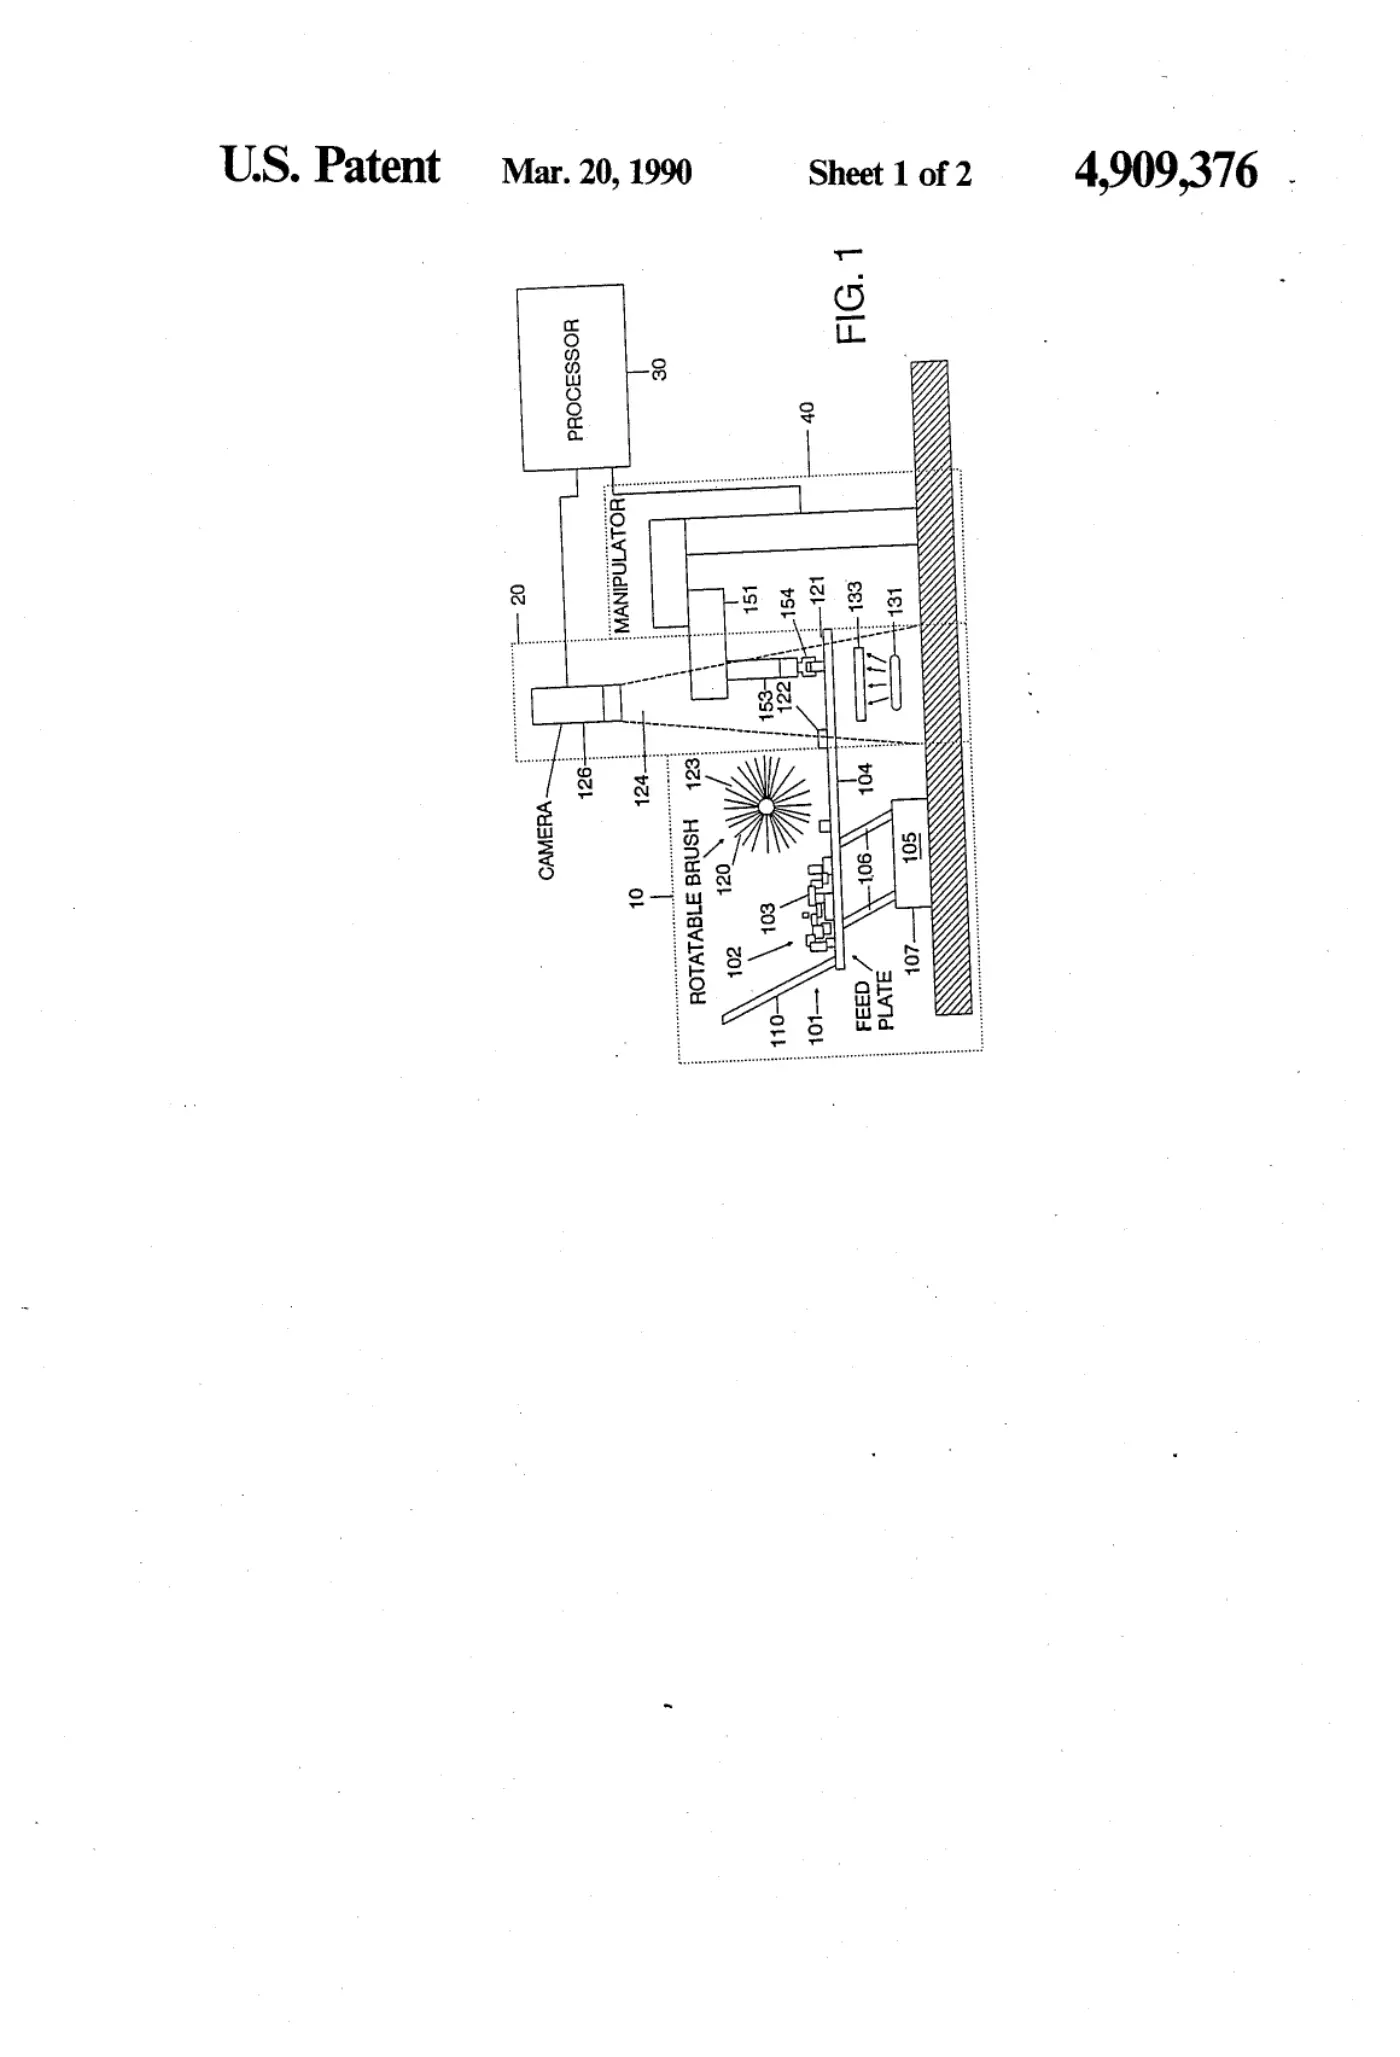
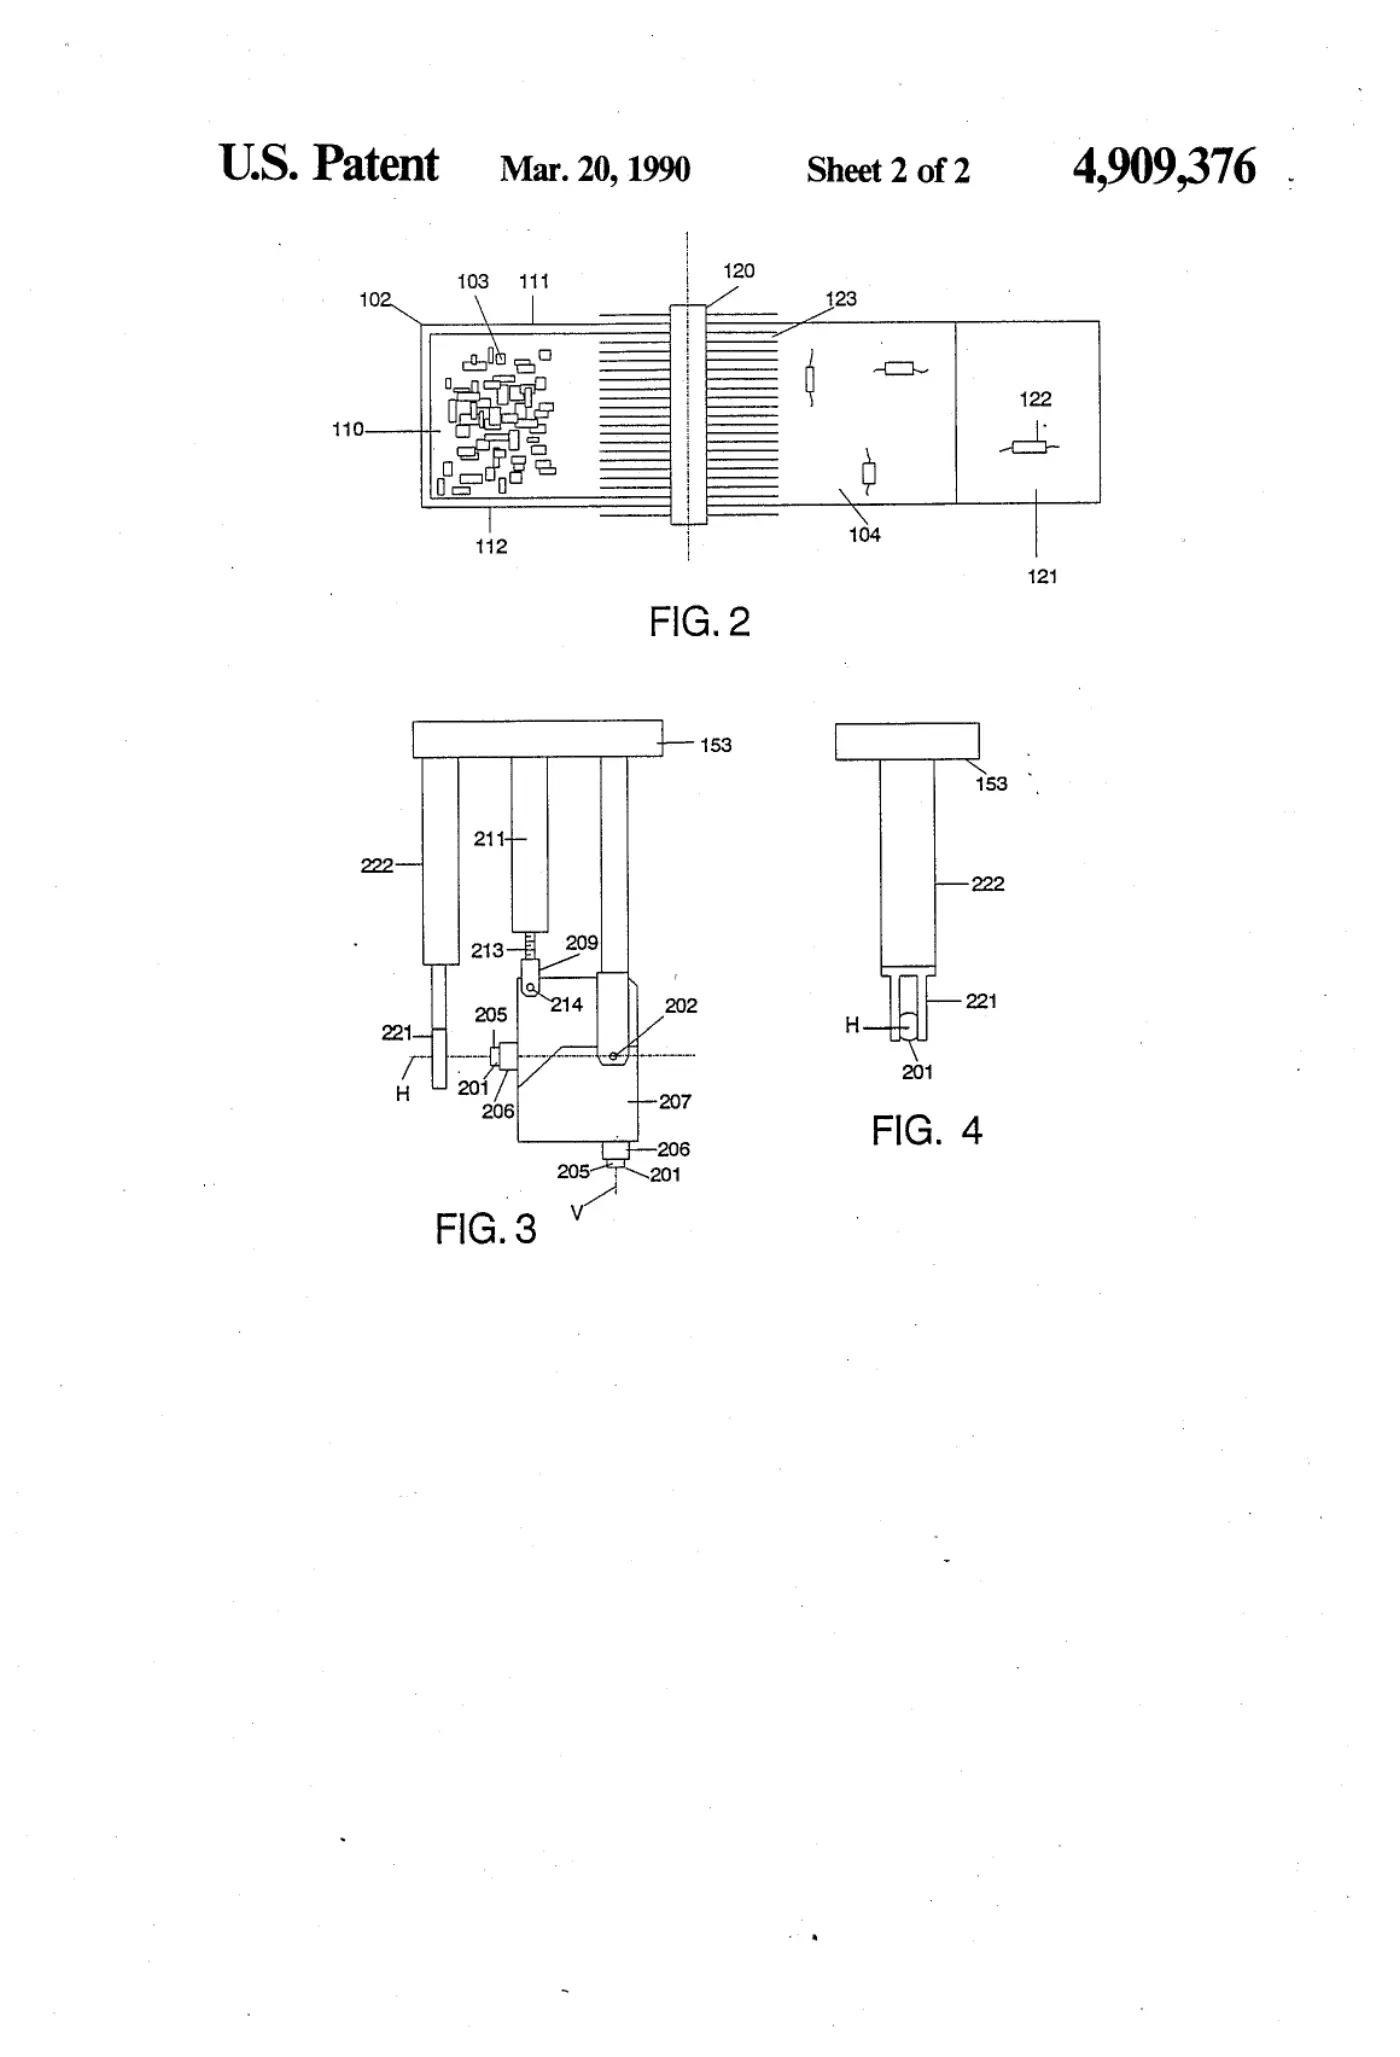
A feed apparatus employs a vision controlled robotic manipulator in which components are dispersed into a single layer with a random orientation. The dispersing mechanism comprises a vibratory feed plate having an input hopper which receives components to be dispersed. The feed plate is controllably vibrated such that components are urged along its top surface. Located in the travel path of the components above the feed plate is a rotating cylindrical brush, which sweeps components as they are being vibrated by the feed plate and causes a single layer of components to emerge from beneath the brush and pass to a viewing/pick-up zone. This zone is backlighted, so that the components may be observed by a camera mounted directly above the backlighted layer. The camera image is analyzed by a video data processor to determine the location and orientation of a component. This information is applied to a manipulator control program for driving a robotic manipulator to pick-up a component for transport to a workpiece. The end effector of the robotic manipulator comprises a vacuum tip mounted to an end of the arm of the manipulator which is pivotable about an axis from a vertical position whereat a component may be seized to a horizontal position. At the horizontal position a set of gripping fingers is provided for seizing a component that has been captured and pivoted thereto by the vacuum tip and which is displaced in the vertical direction to cause the component to be released by the vacuum tip.
Abstract
A feed apparatus employs a vision controlled robotic manipulator in which components are dispersed into a single layer with a random orientation. The dispersing mechanism comprises a vibratory feed plate having an input hopper which receives components to be dispersed. The feed plate is controllably vibrated such that components are urged along its top surface. Located in the travel path of the components above the feed plate is a rotating cylindrical brush, which sweeps components as they are being vibrated by the feed plate and causes a single layer of components to emerge from beneath the brush and pass to a viewing/pick-up zone. This zone is backlighted, so that the components may be observed by a camera mounted directly above the backlighted layer. The camera image is analyzed by a video data processor to determine the location and orientation of a component. This information is applied to a manipulator control program for driving a robotic manipulator to pick-up a component for transport to a workpiece. The end effector of the robotic manipulator comprises a vacuum tip mounted to an end of the arm of the manipulator which is pivotable about an axis from a vertical position whereat a component may be seized to a horizontal position. At the horizontal position a set of gripping fingers is provided for seizing a component that has been captured and pivoted thereto by the vacuum tip and which is displaced in the vertical direction to cause the component to be released by the vacuum tip.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
Publication information
Citation
OpenTechnical Publication OT-2026-000003464, “Robotically controlled component feed mechanism visually monitoring part orientation,” published September 15, 2026 at 20:31:07 UTC, https://opentechnical.org/p/OT-2026-000003464.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.