OT-2026-000003466
Direct-drive-type multi-articulated robot
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003466
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- KIKUCHI JUN, NIHEI RYO, TERADA AKIHIRO, TORII NOBUTOSHI, TOYODA KENICHI
- Assignee
- FANUC LTD
- Original source
- US-4903539-A, the United States Patent and Trademark Office, 27 February 1990
- Document SHA-256
- bf98eafb8c603e466f044a1d8e14ff399eee27f0ff09c38680ab016287277062
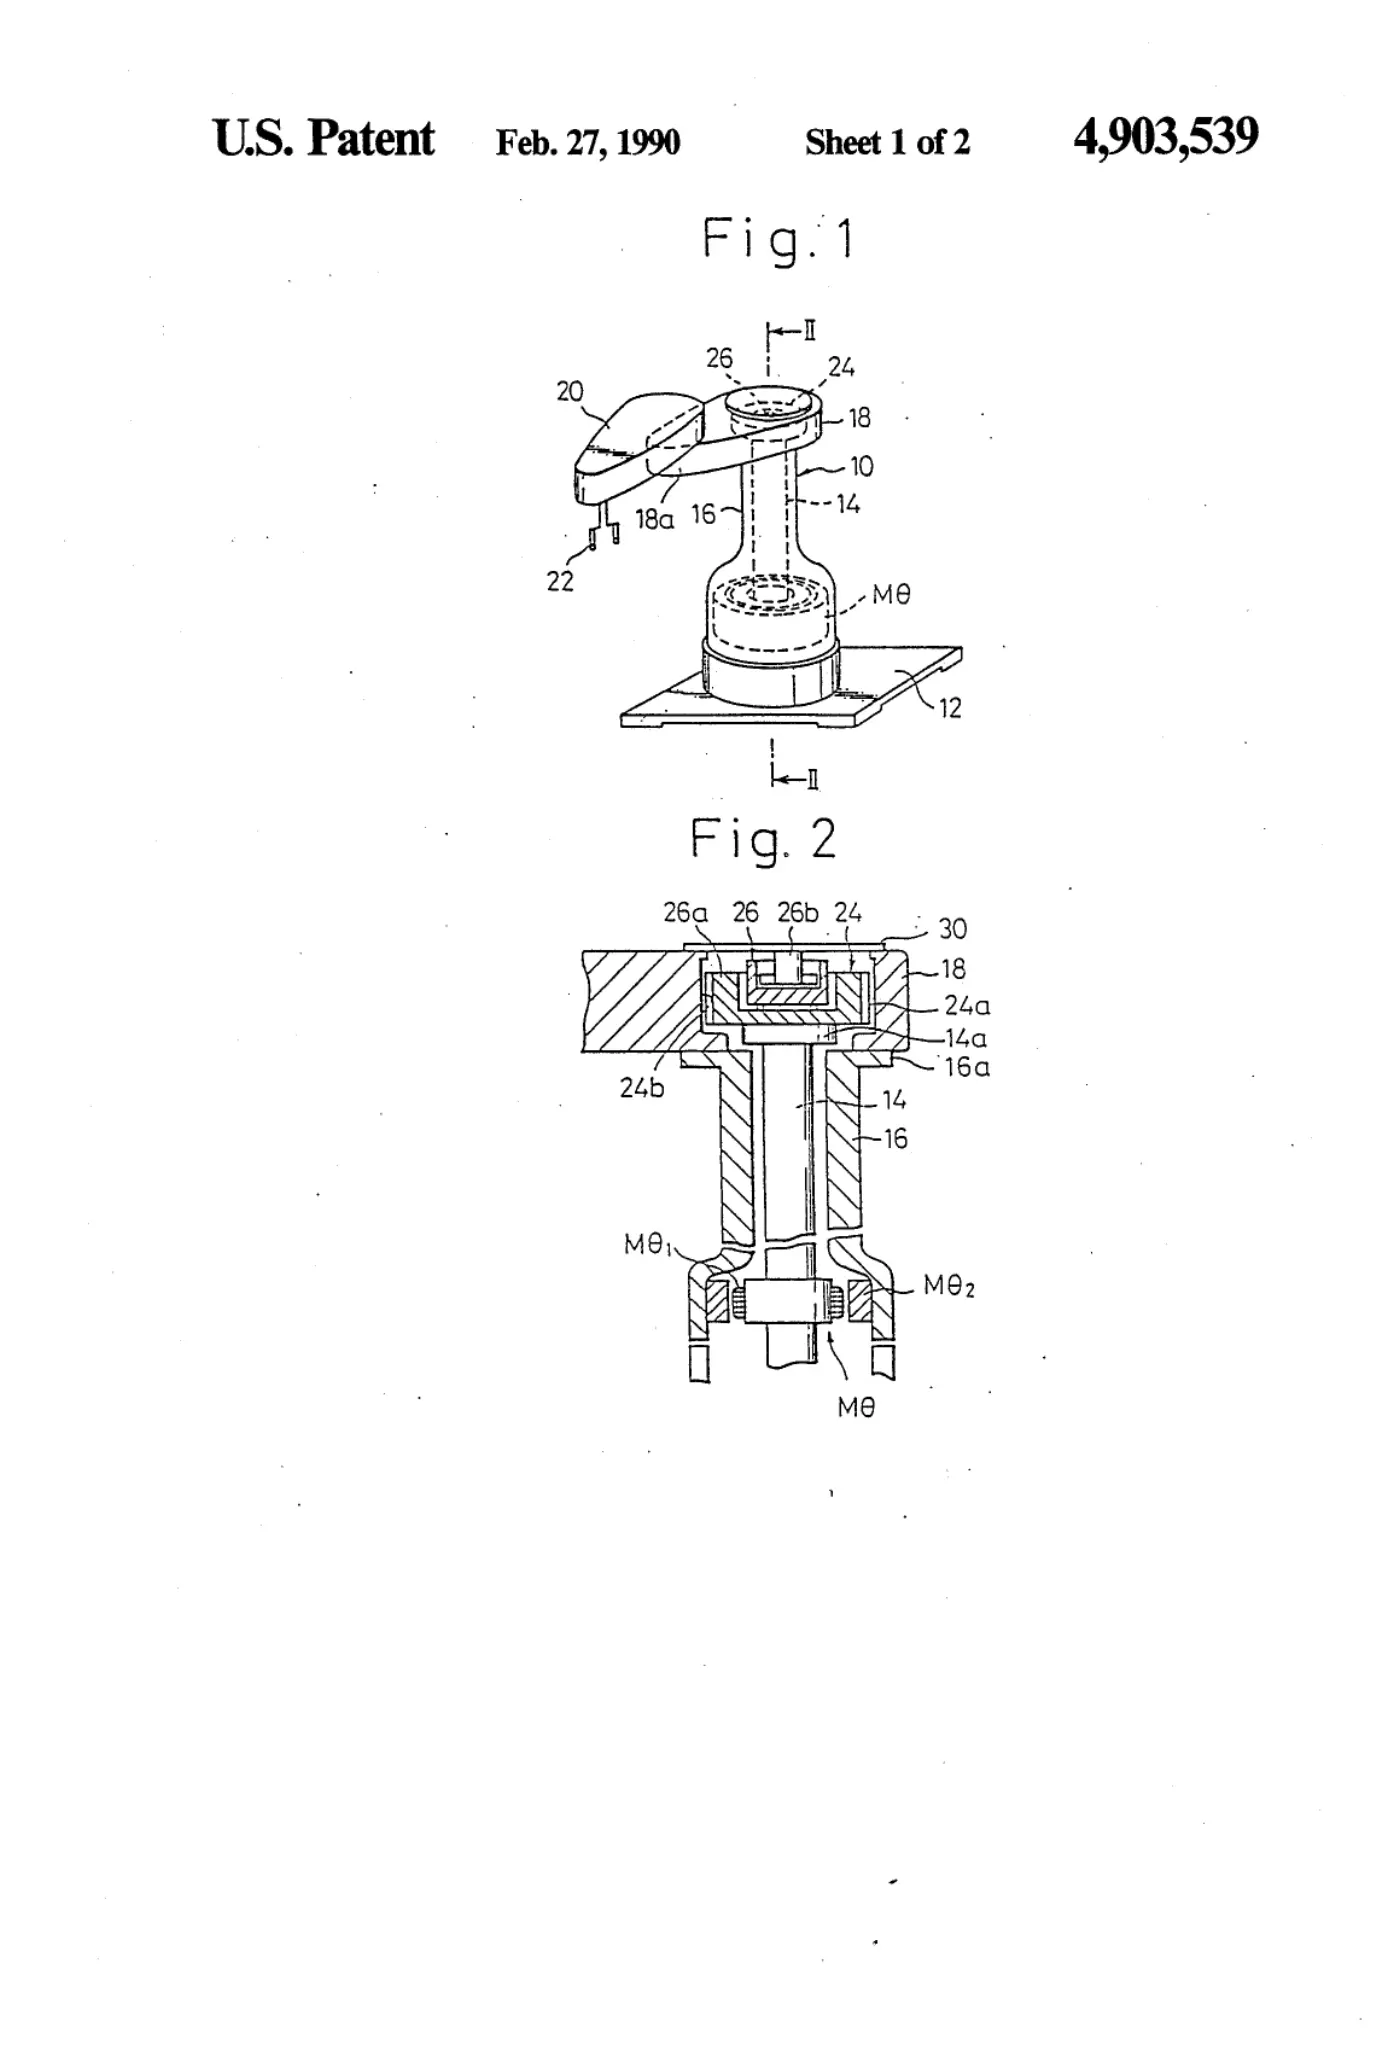
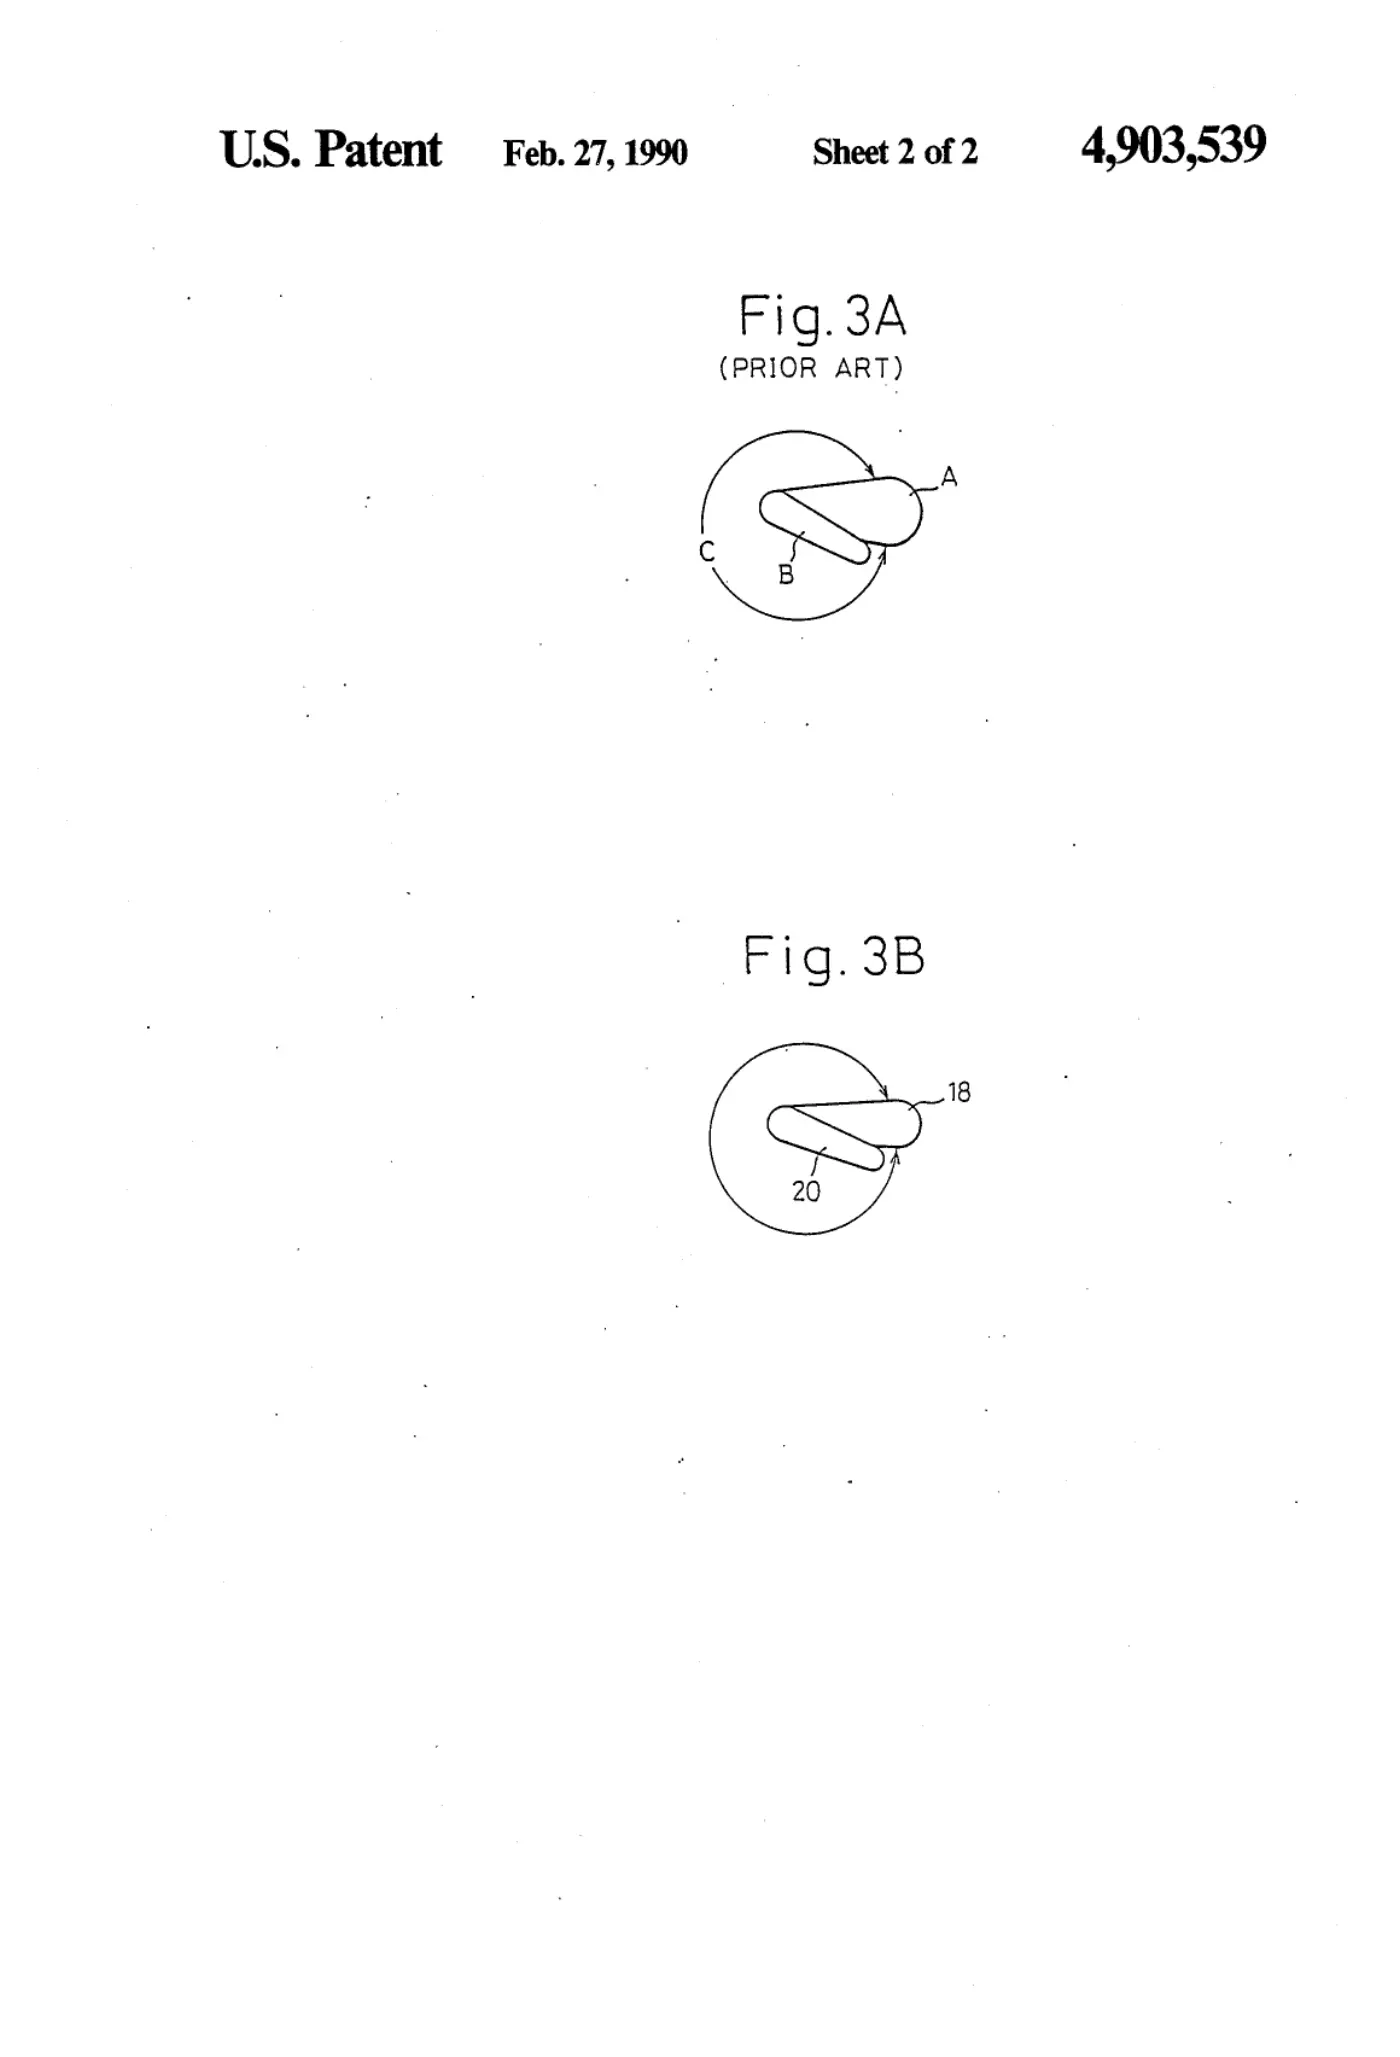
A direct-drive-type multi-articulated robot comprising: a stationary support shaft (14), a cylindrical rotary casing (16) surrounding the stationary support shaft (14), a first robot arm (18) joined to the upper end (16a) of the rotary casing (16), a second robot arm (20) pivotally joined to the extremity of the first robot arm (18), a direct-drive motor (Mθ) interposed between the lower end of the rotary casing (16) and the lower end of the stationary support shaft (14) to drive the rotary casing (16) and the first robot arm (18) together for turning motion, a brake gear (24) interposed between the upper end (14a) of the stationary support shaft (14) and the first robot arm (18) to arrest the turning motion of the first robot arm (18), and an encoder (26) for detecting turning motion, interposed between the upper end (14a) of the stationary support shaft (14) and the first robot arm (18).
Abstract
A direct-drive-type multi-articulated robot comprising: a stationary support shaft (14), a cylindrical rotary casing (16) surrounding the stationary support shaft (14), a first robot arm (18) joined to the upper end (16a) of the rotary casing (16), a second robot arm (20) pivotally joined to the extremity of the first robot arm (18), a direct-drive motor (Mθ) interposed between the lower end of the rotary casing (16) and the lower end of the stationary support shaft (14) to drive the rotary casing (16) and the first robot arm (18) together for turning motion, a brake gear (24) interposed between the upper end (14a) of the stationary support shaft (14) and the first robot arm (18) to arrest the turning motion of the first robot arm (18), and an encoder (26) for detecting turning motion, interposed between the upper end (14a) of the stationary support shaft (14) and the first robot arm (18).
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
Publication information
Citation
OpenTechnical Publication OT-2026-000003466, “Direct-drive-type multi-articulated robot,” published September 15, 2026 at 20:31:12 UTC, https://opentechnical.org/p/OT-2026-000003466.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.