OT-2026-000003467
Robot arm for an industrial robot
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003467
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- LARSSON OVE
- Assignee
- KOMATSU MFG CO LTD
- Original source
- US-4904148-A, the United States Patent and Trademark Office, 27 February 1990
- Document SHA-256
- c794071bbdbdf376dfa4e81f89c0e183df81f9c7601d8ec7c1c8d202083cb2d2
A robot arm usable for an industrial robot adapted to freely bend to realize a pattern of movement having a high ability of movement, excellent reachability and high accuracy by virtue of a comparatively small amount of rotational movement and a comparatively large amount of translational movement. The robot arm has cylindrical arm portions (14, 15, 16) flexibly connected to one after another via joints, and the arm portions comprise one upper arm (14), at least one intermediate arm (15) and one lower arm (16). An arm portion which belongs to a certain joint is formed with joint faces (21) which are inclined with respect to a longitudinally extending axis (29). A joint axis (22) of this joint extends at a right angle with respect to each of the joint faces (21). Each of the arm portions is freely turnable about the joint axis (22) independently of adjacent one or plural arm portions. Additionally, inclined joint faces located at opposite ends of the intermediate arm are formed in such a manner that their extensions intersect one another at a position located outwardly of the outer boundary of the intermediate arm.
Abstract
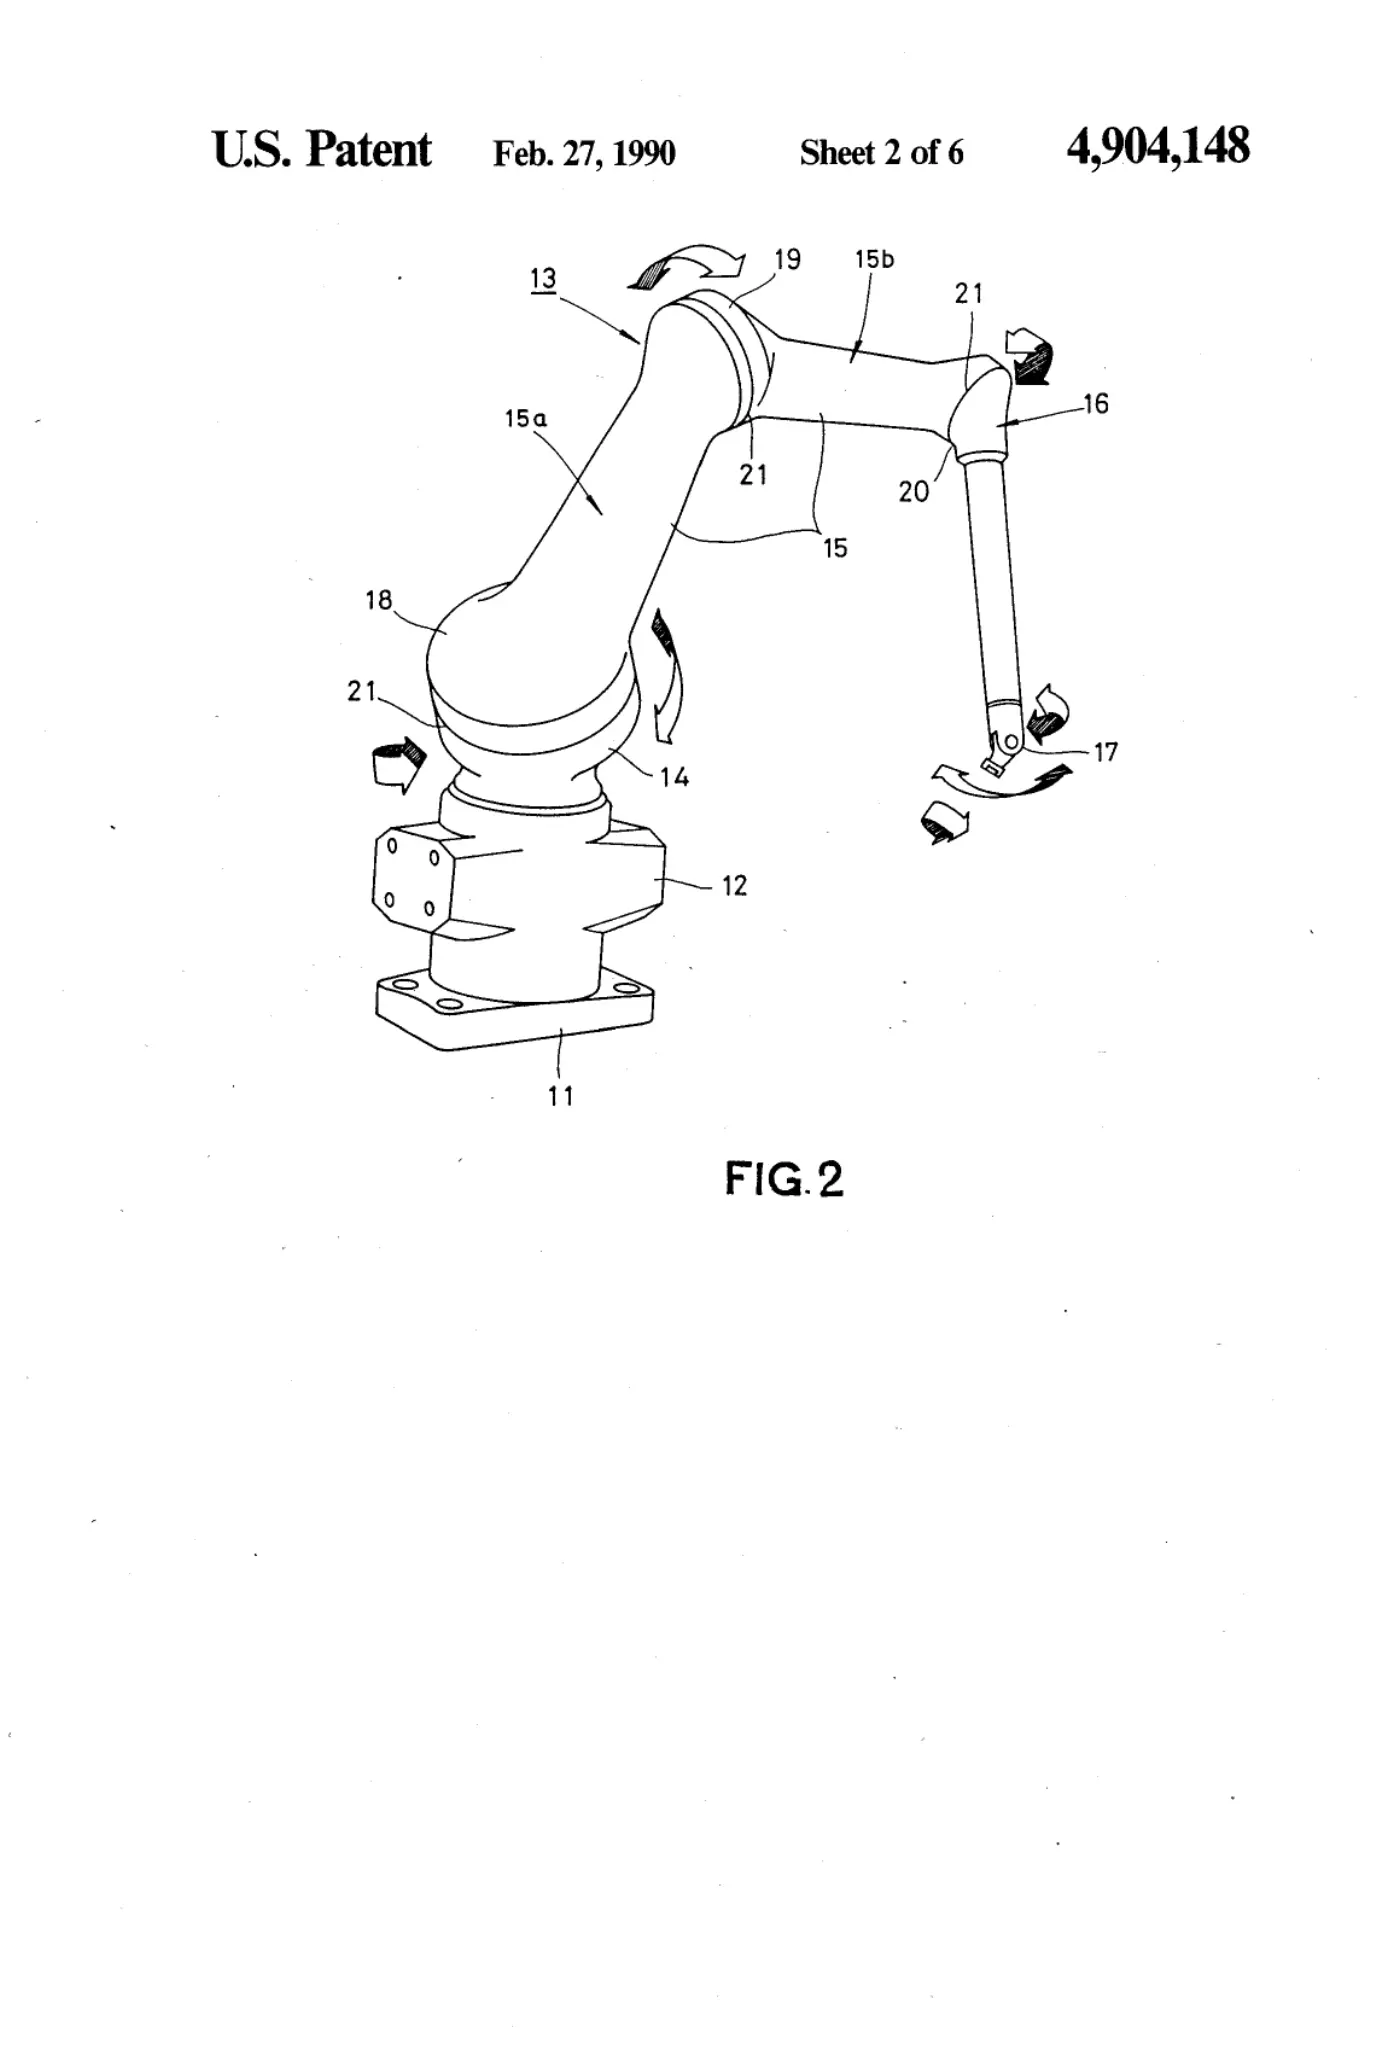
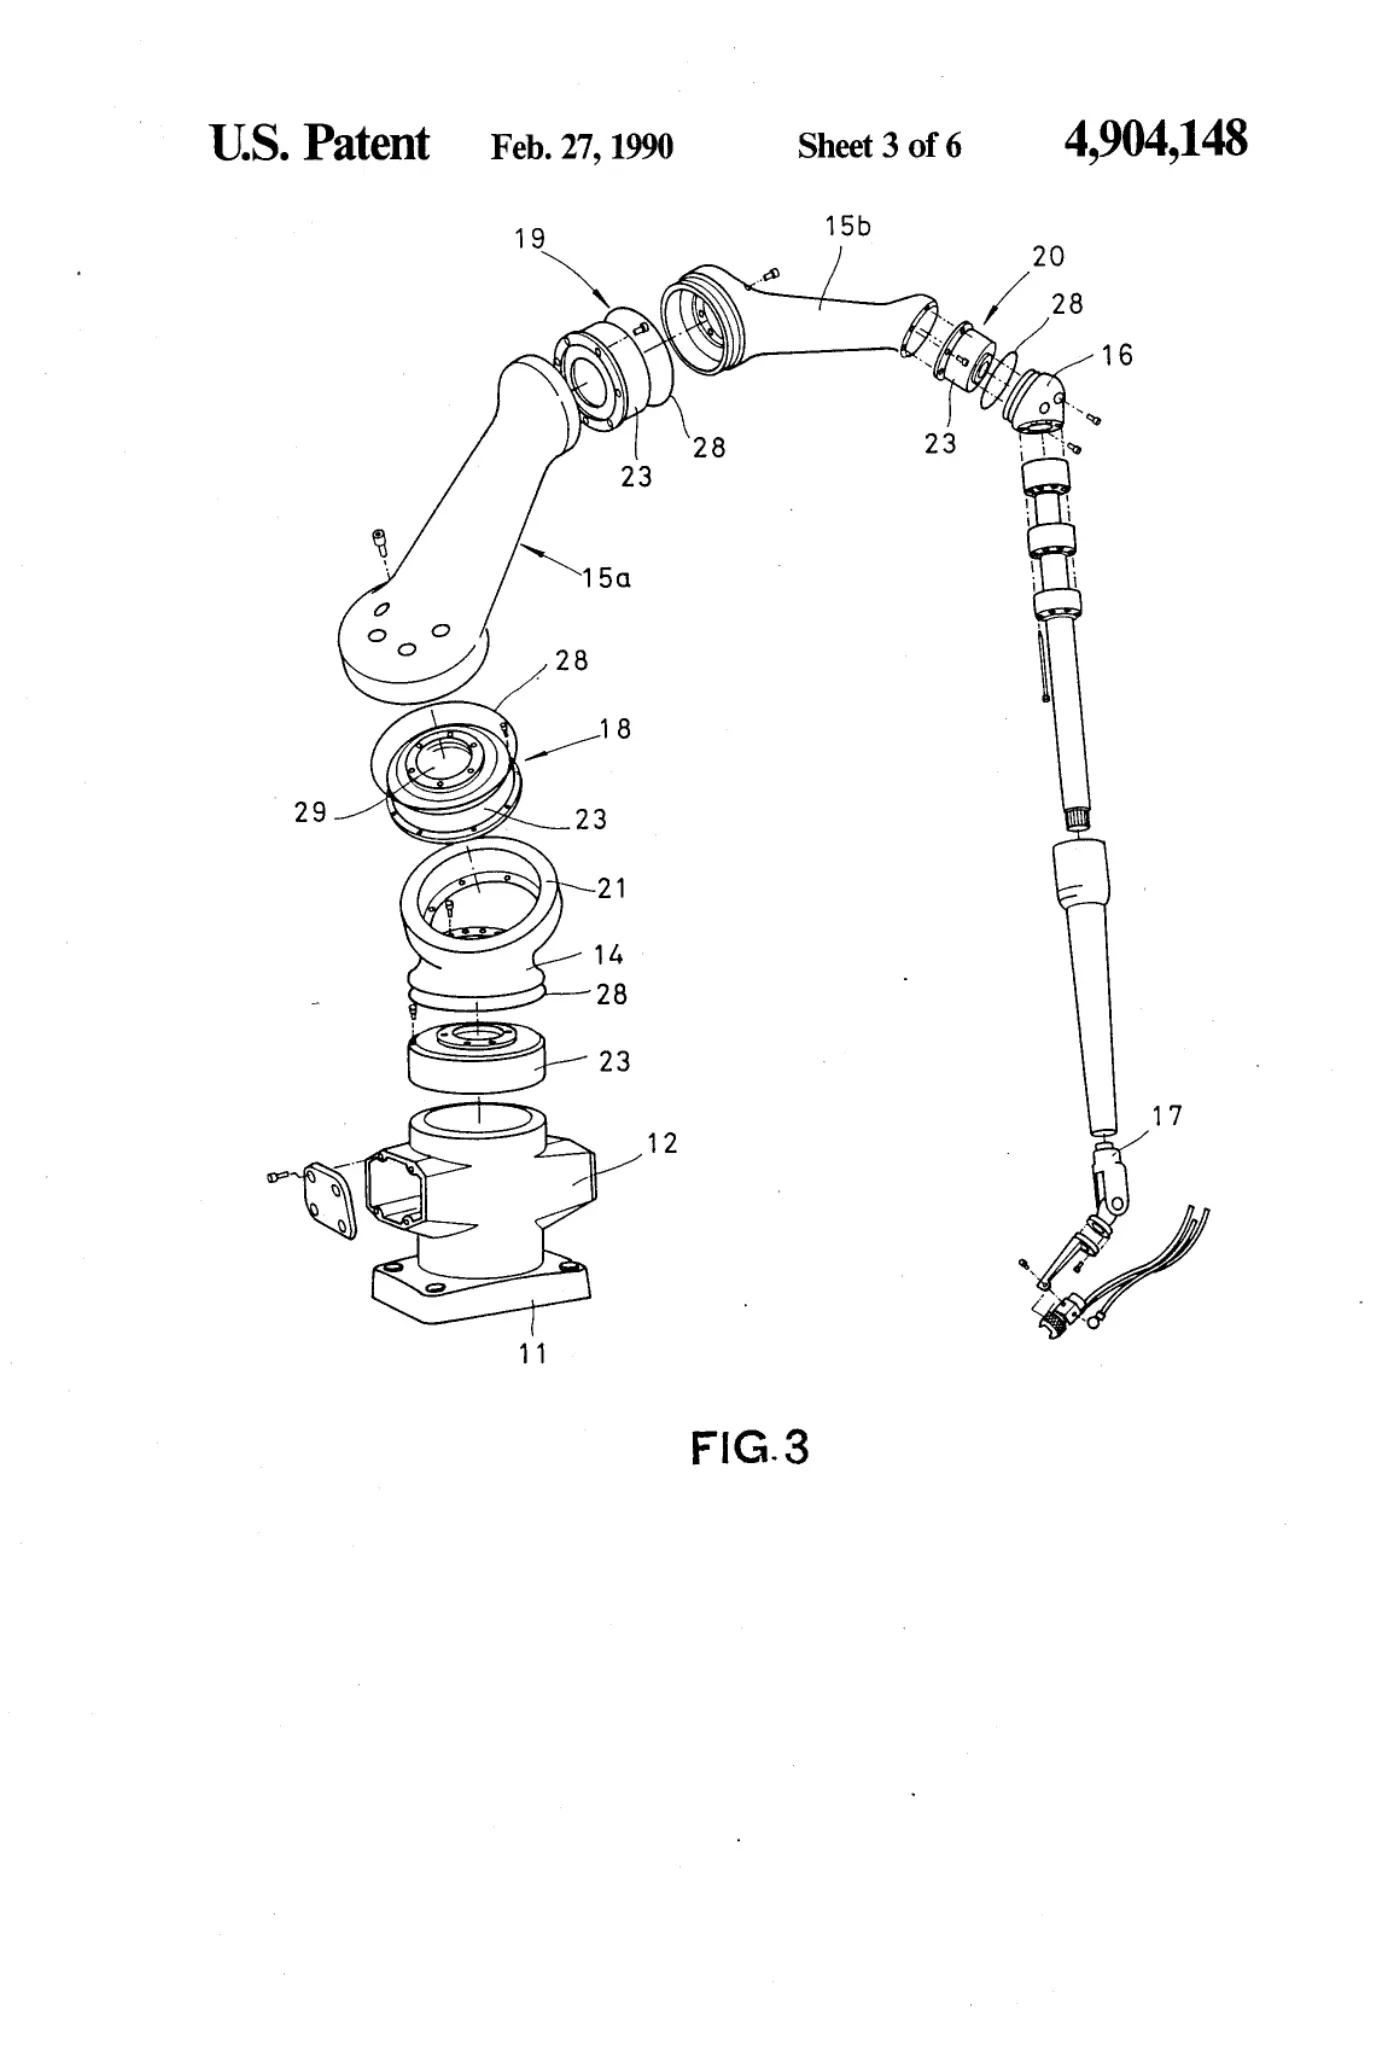
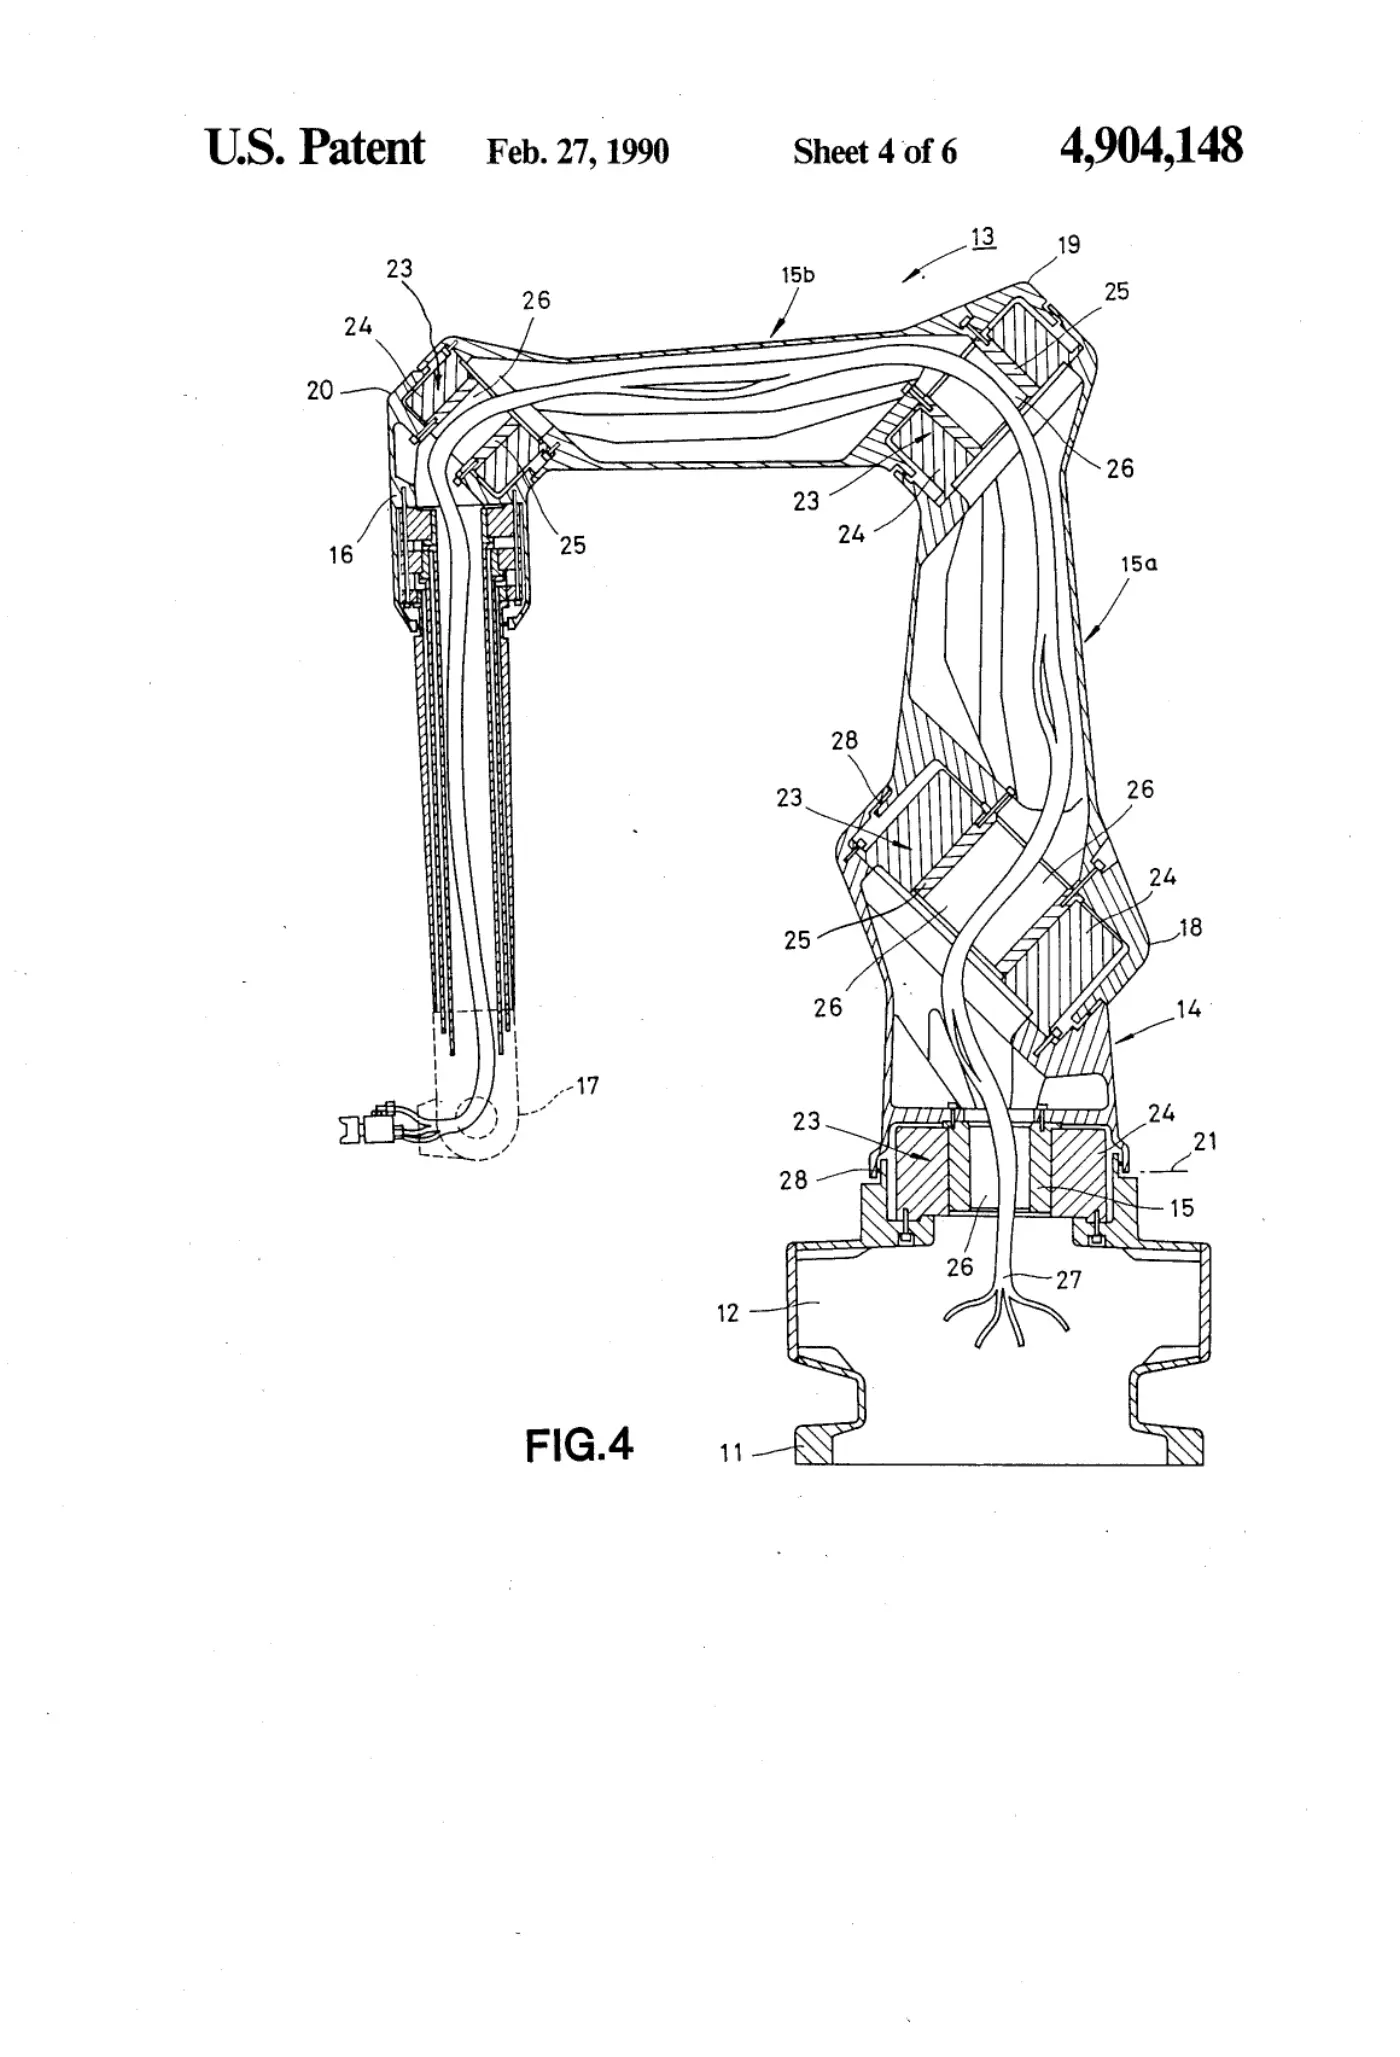
A robot arm usable for an industrial robot adapted to freely bend to realize a pattern of movement having a high ability of movement, excellent reachability and high accuracy by virtue of a comparatively small amount of rotational movement and a comparatively large amount of translational movement. The robot arm has cylindrical arm portions (14, 15, 16) flexibly connected to one after another via joints, and the arm portions comprise one upper arm (14), at least one intermediate arm (15) and one lower arm (16). An arm portion which belongs to a certain joint is formed with joint faces (21) which are inclined with respect to a longitudinally extending axis (29). A joint axis (22) of this joint extends at a right angle with respect to each of the joint faces (21). Each of the arm portions is freely turnable about the joint axis (22) independently of adjacent one or plural arm portions. Additionally, inclined joint faces located at opposite ends of the intermediate arm are formed in such a manner that their extensions intersect one another at a position located outwardly of the outer boundary of the intermediate arm.
1. Drawings
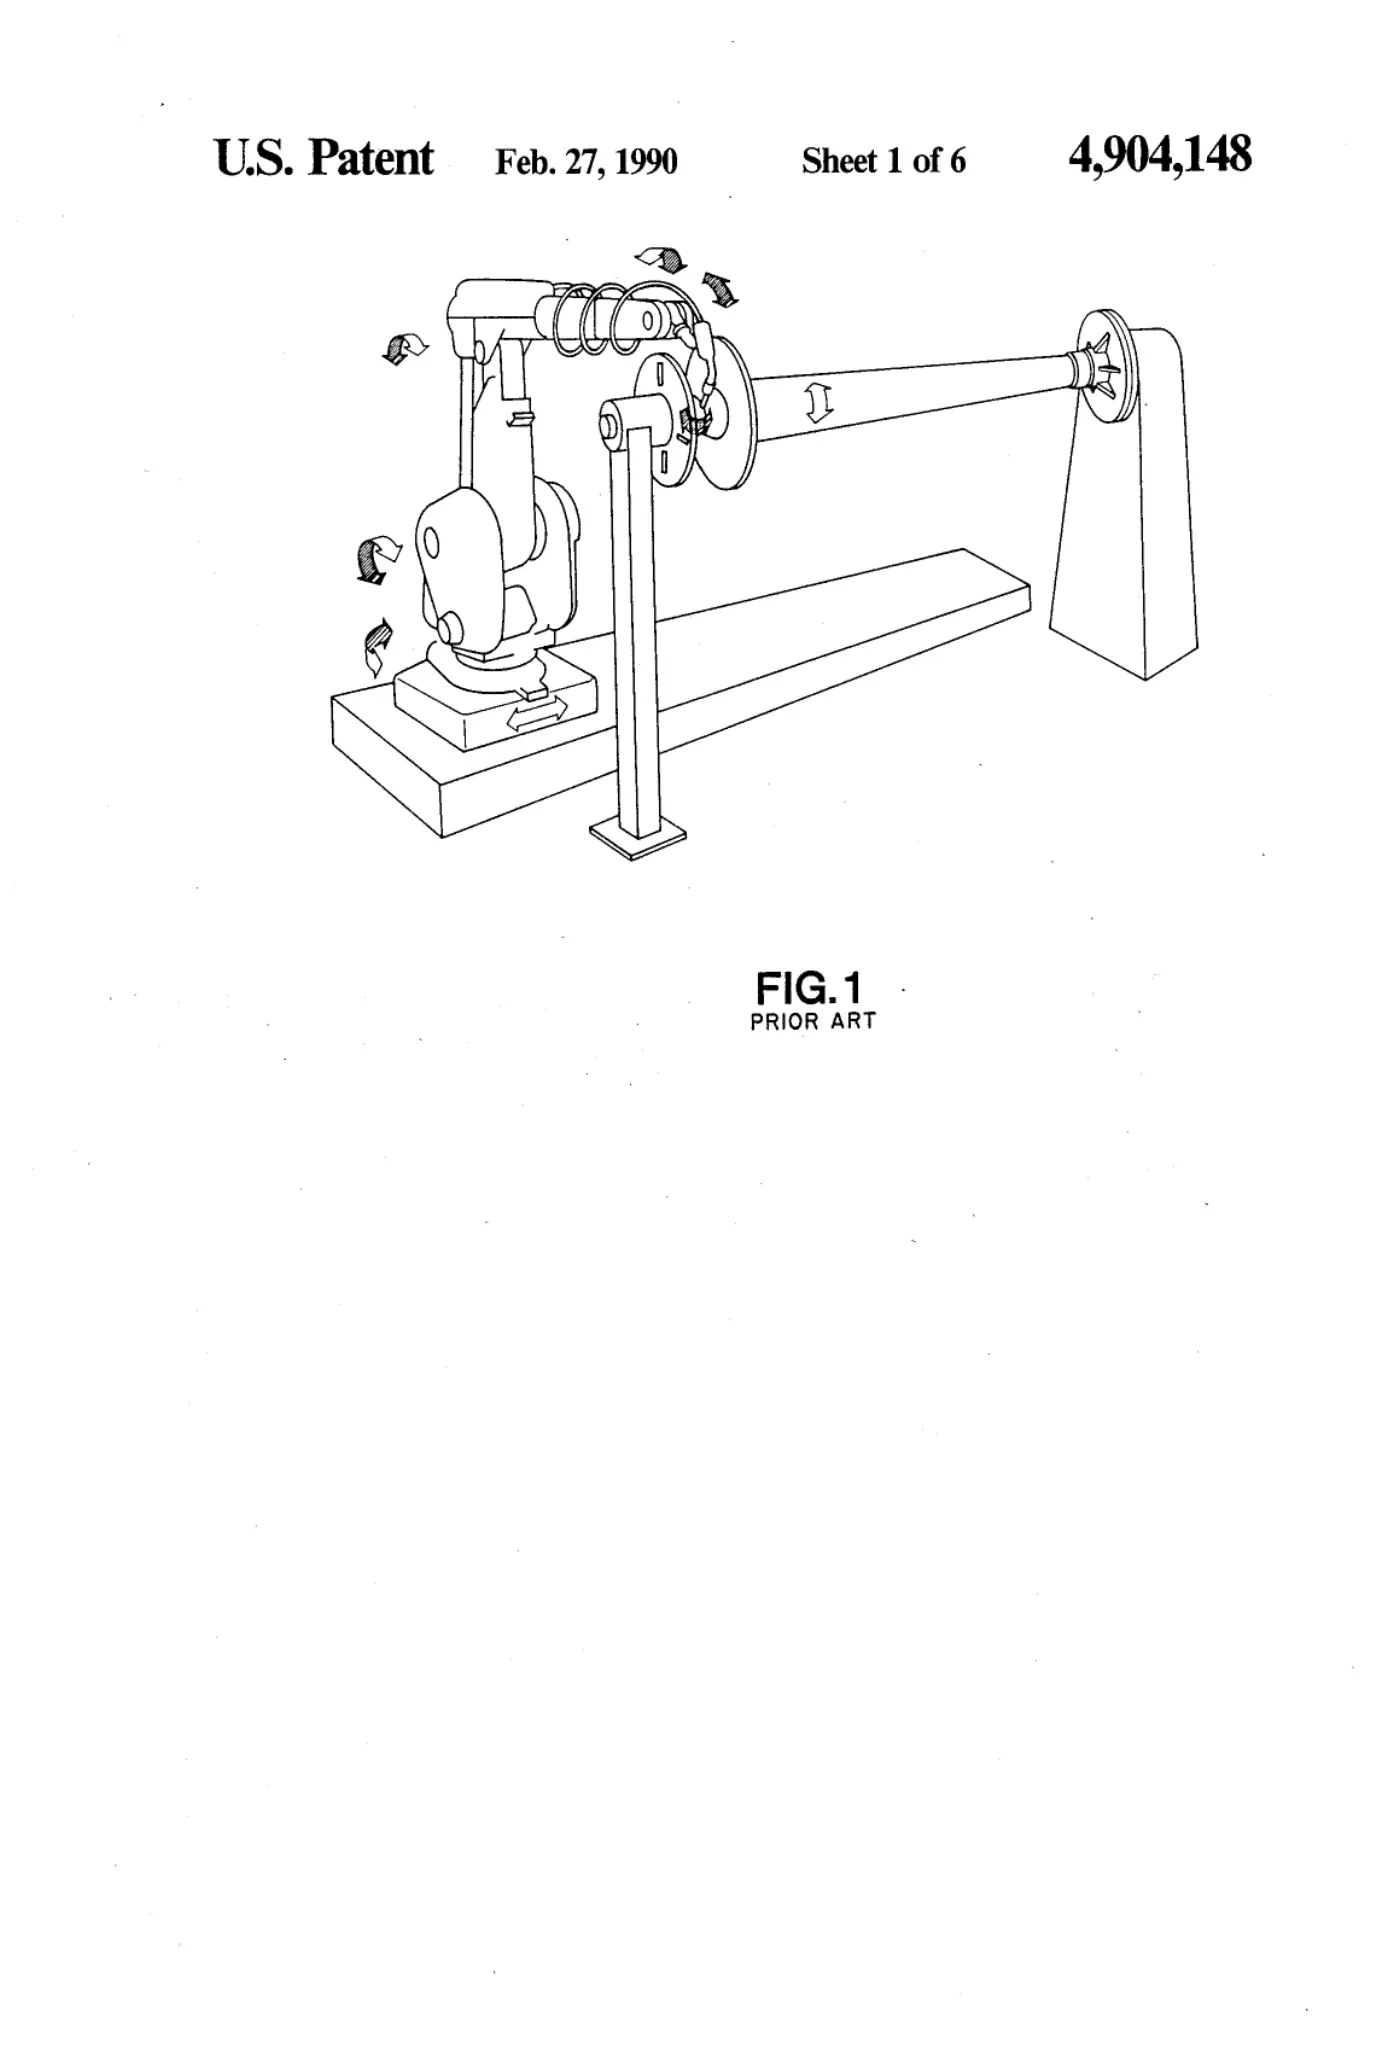
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
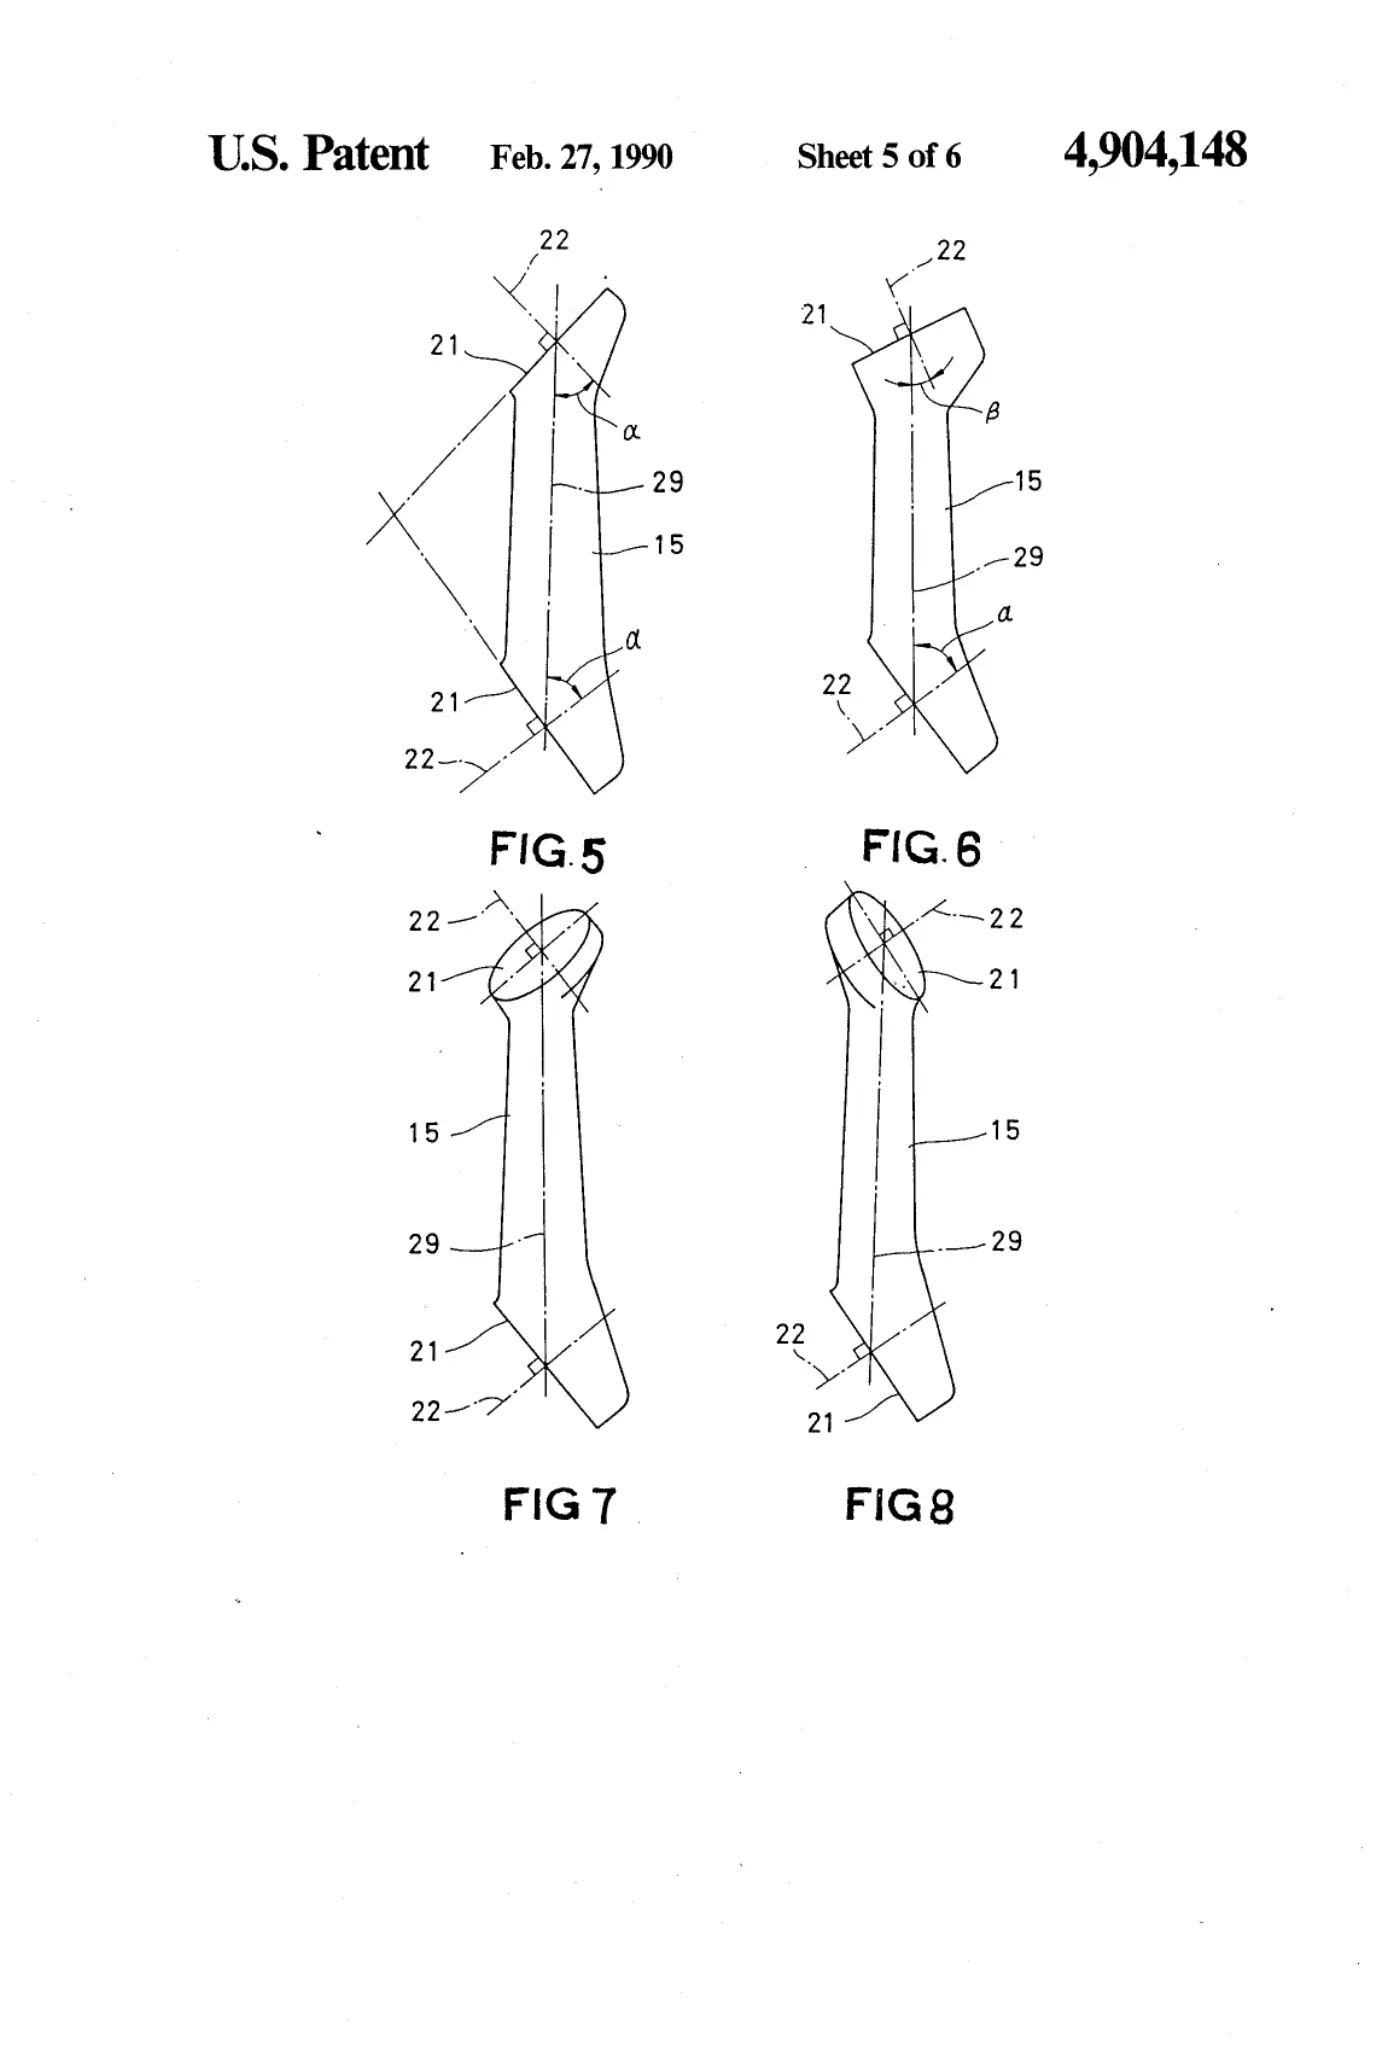
[0005]Sheet 5.
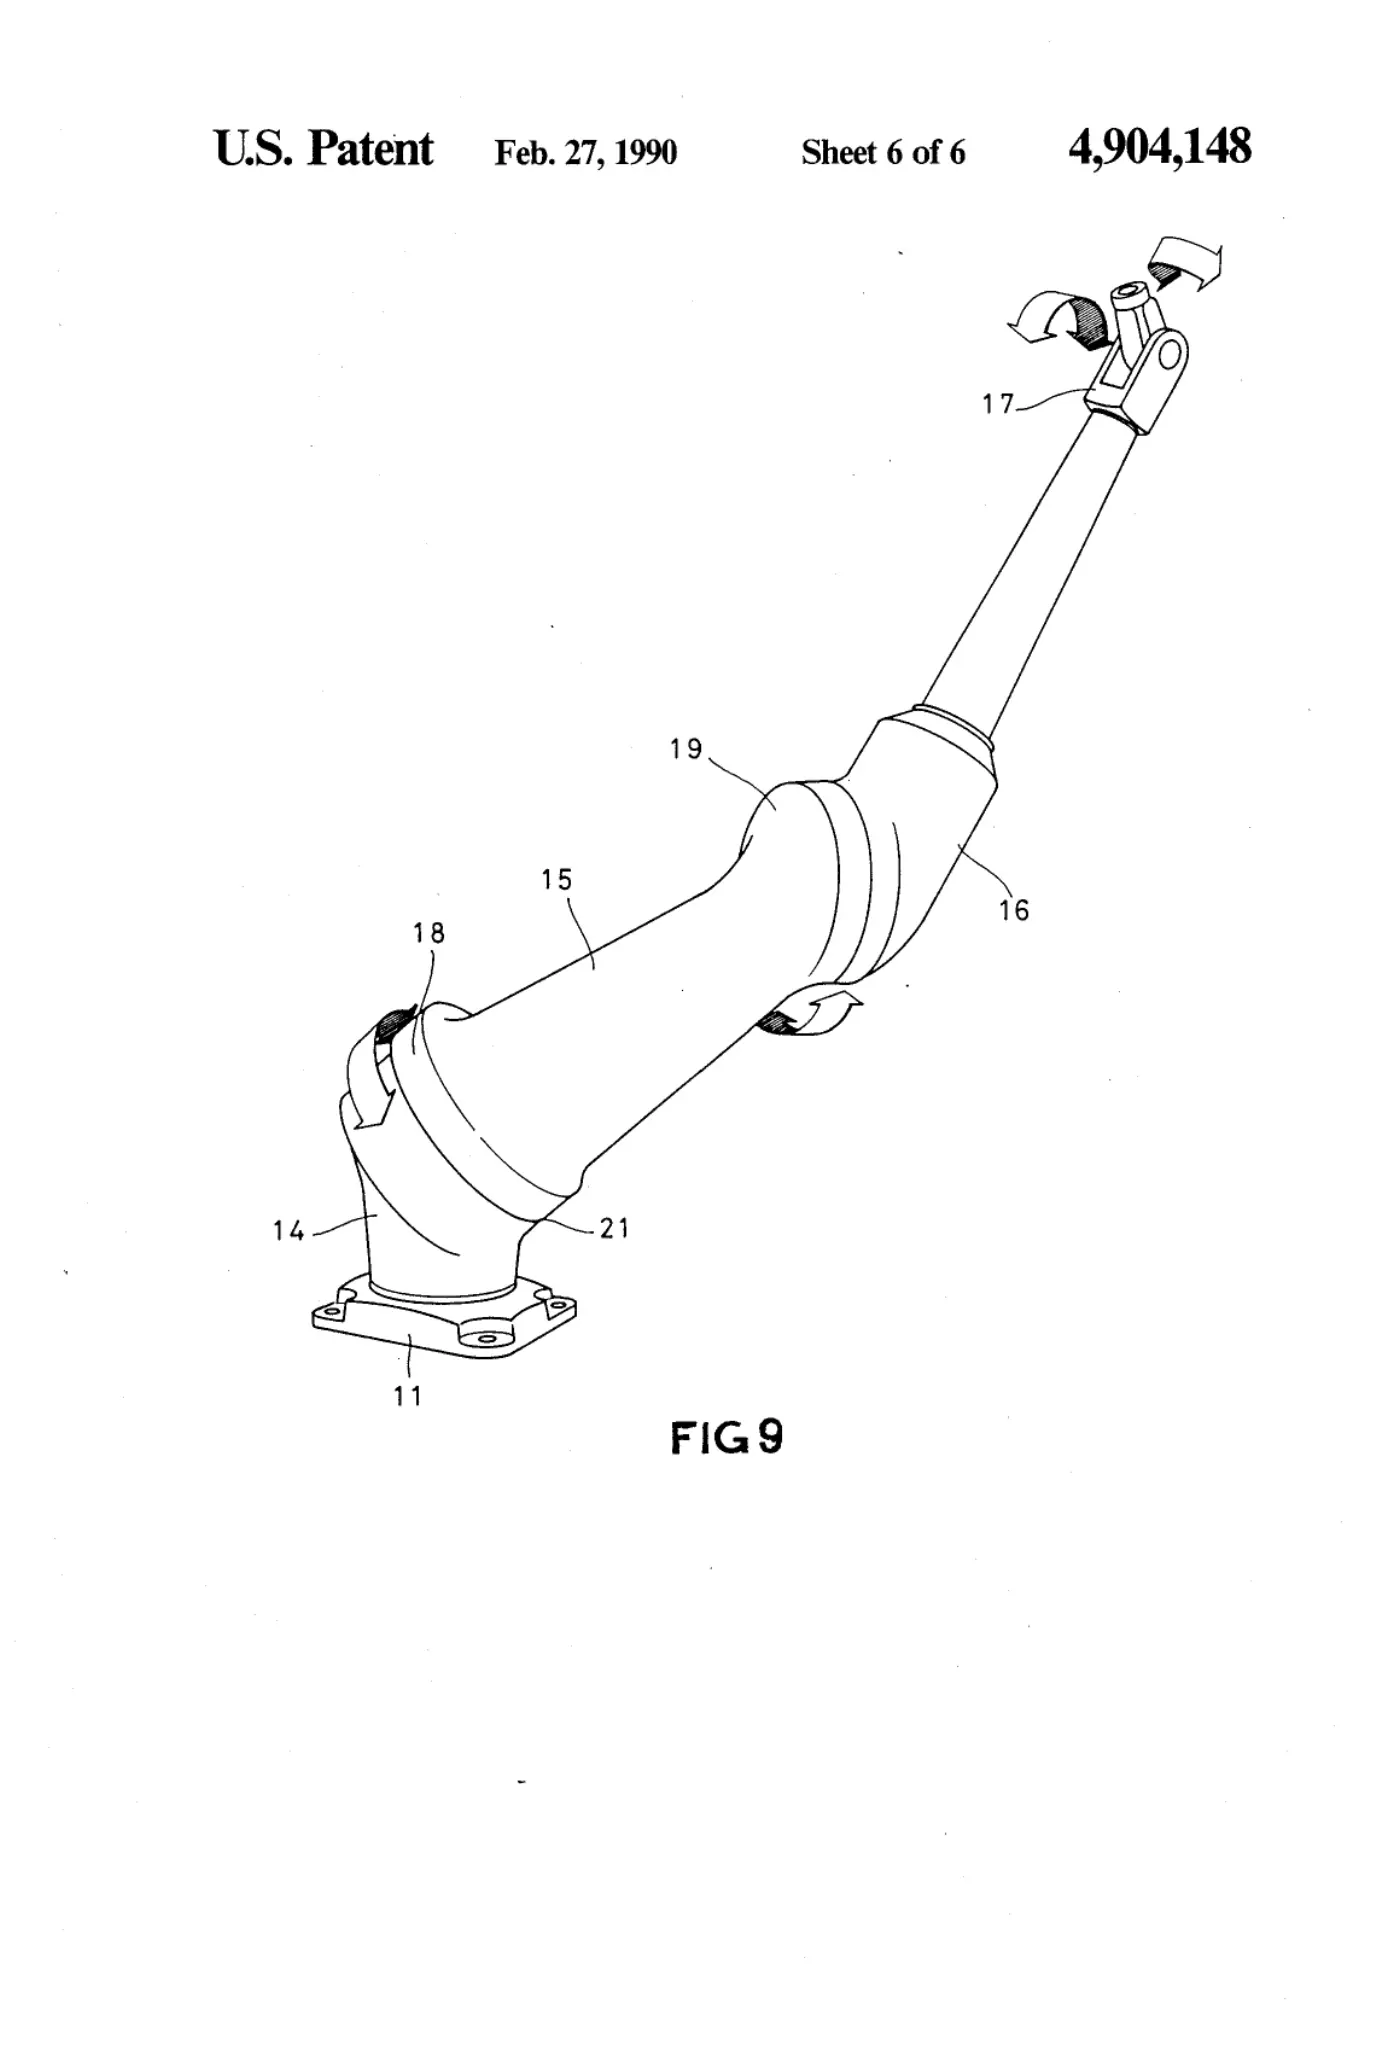
[0006]Sheet 6.
Publication information
Citation
OpenTechnical Publication OT-2026-000003467, “Robot arm for an industrial robot,” published September 15, 2026 at 20:31:23 UTC, https://opentechnical.org/p/OT-2026-000003467.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.