OT-2026-000003479
Manipulator for handling objects within a sealed chamber
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003479
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- CASHELL EDMUND M, MCDONNELL LIAM
- Assignee
- TEKSCAN LTD
- Original source
- US-4850779-A, the United States Patent and Trademark Office, 25 July 1989
- Document SHA-256
- f2d9a1faa8c1c073ea80b4b9eebda512bd0790d858d30dacd419cafef9c3af3e
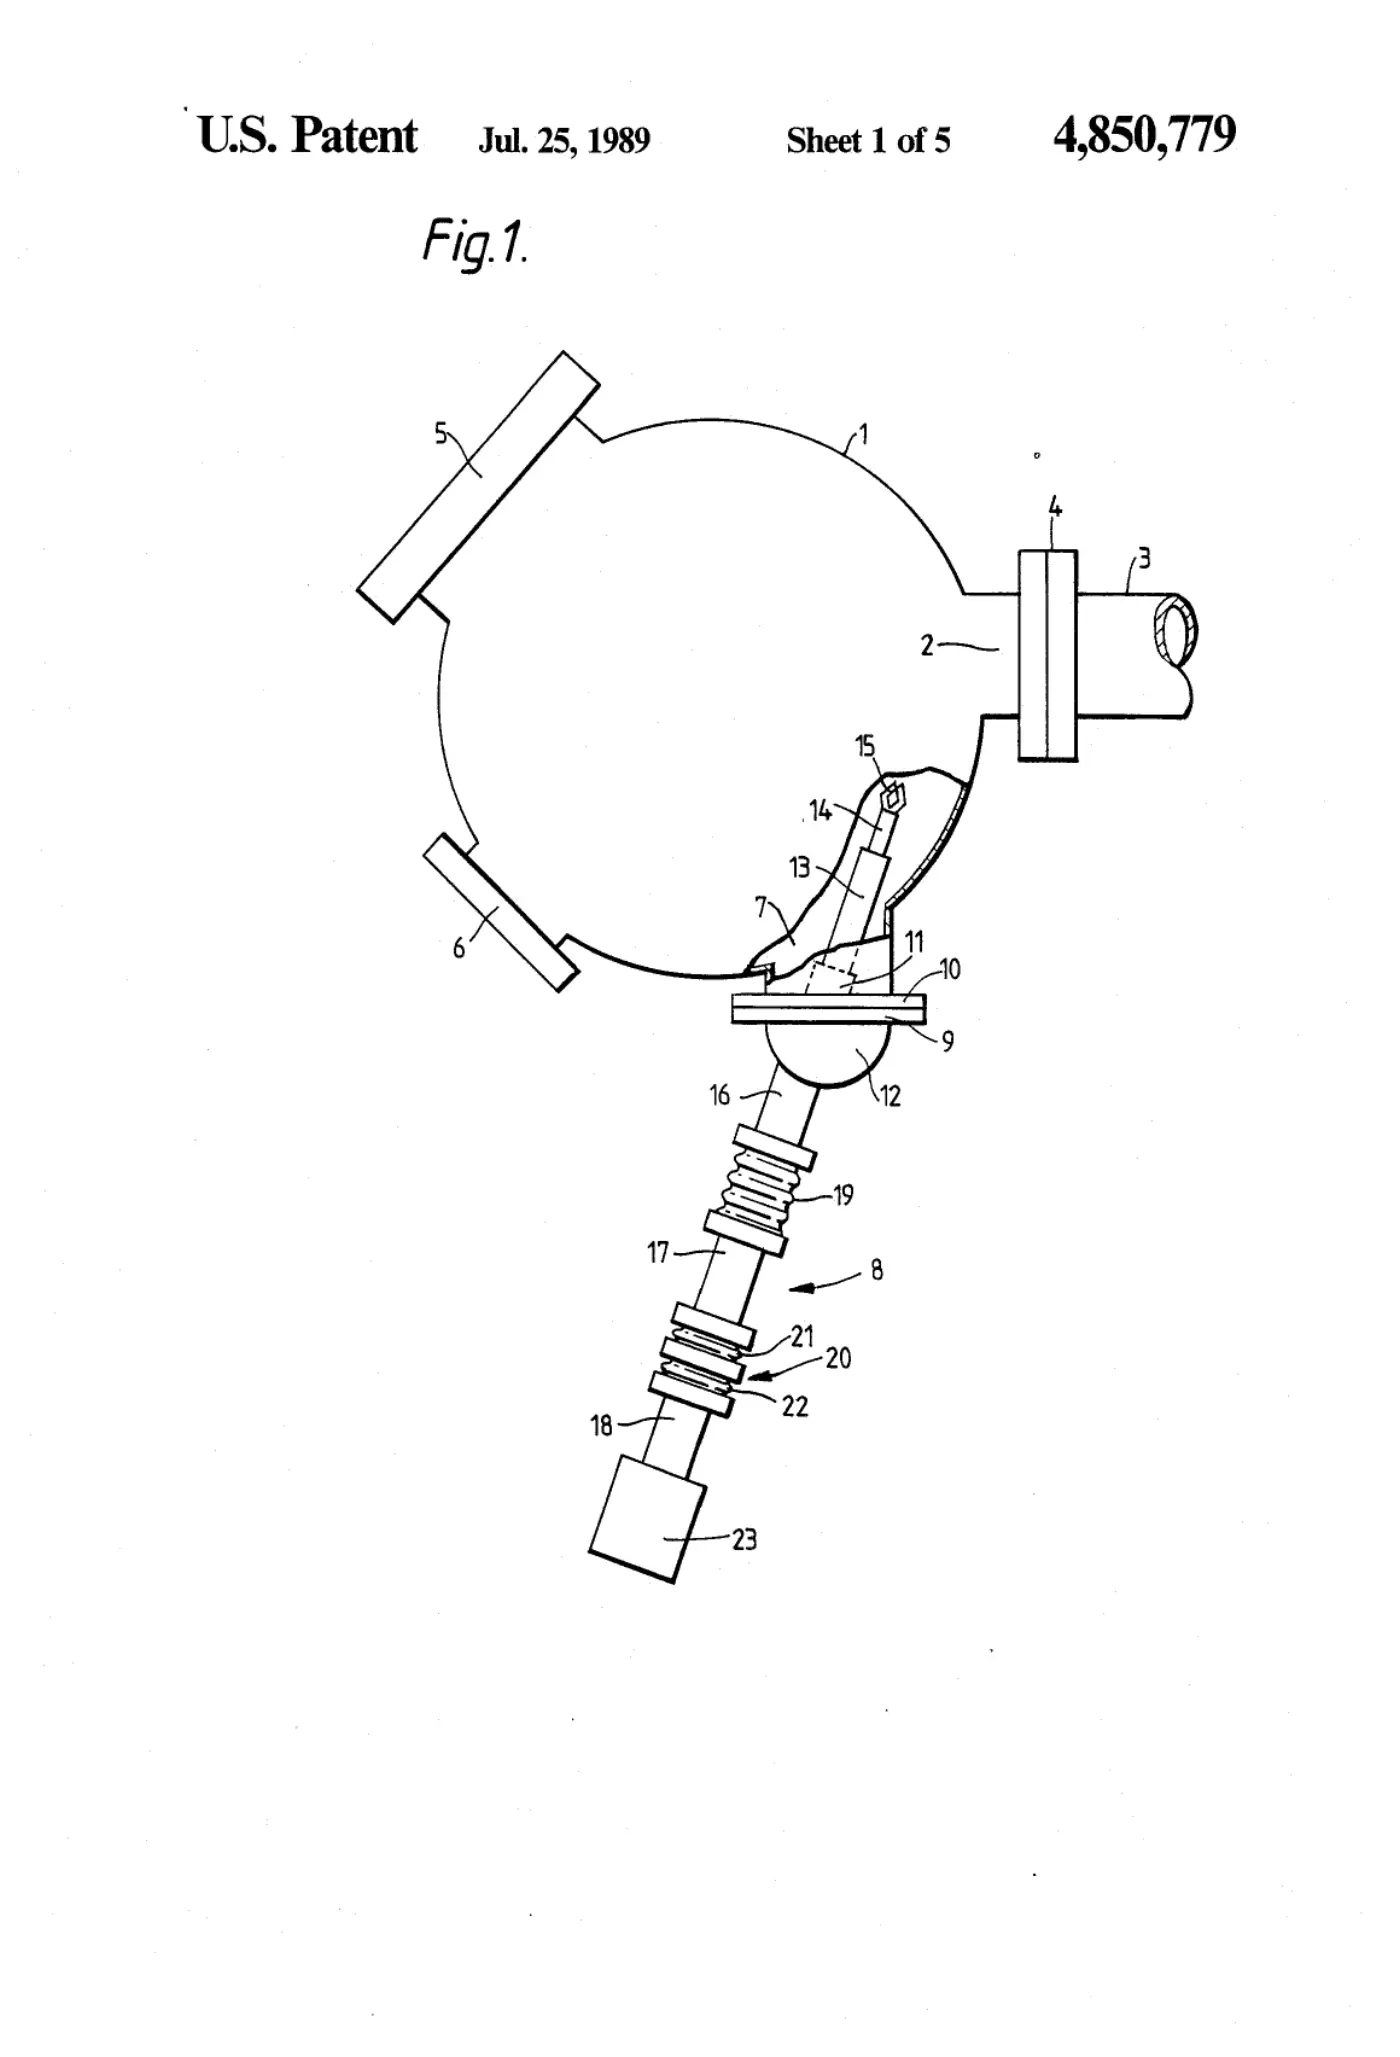
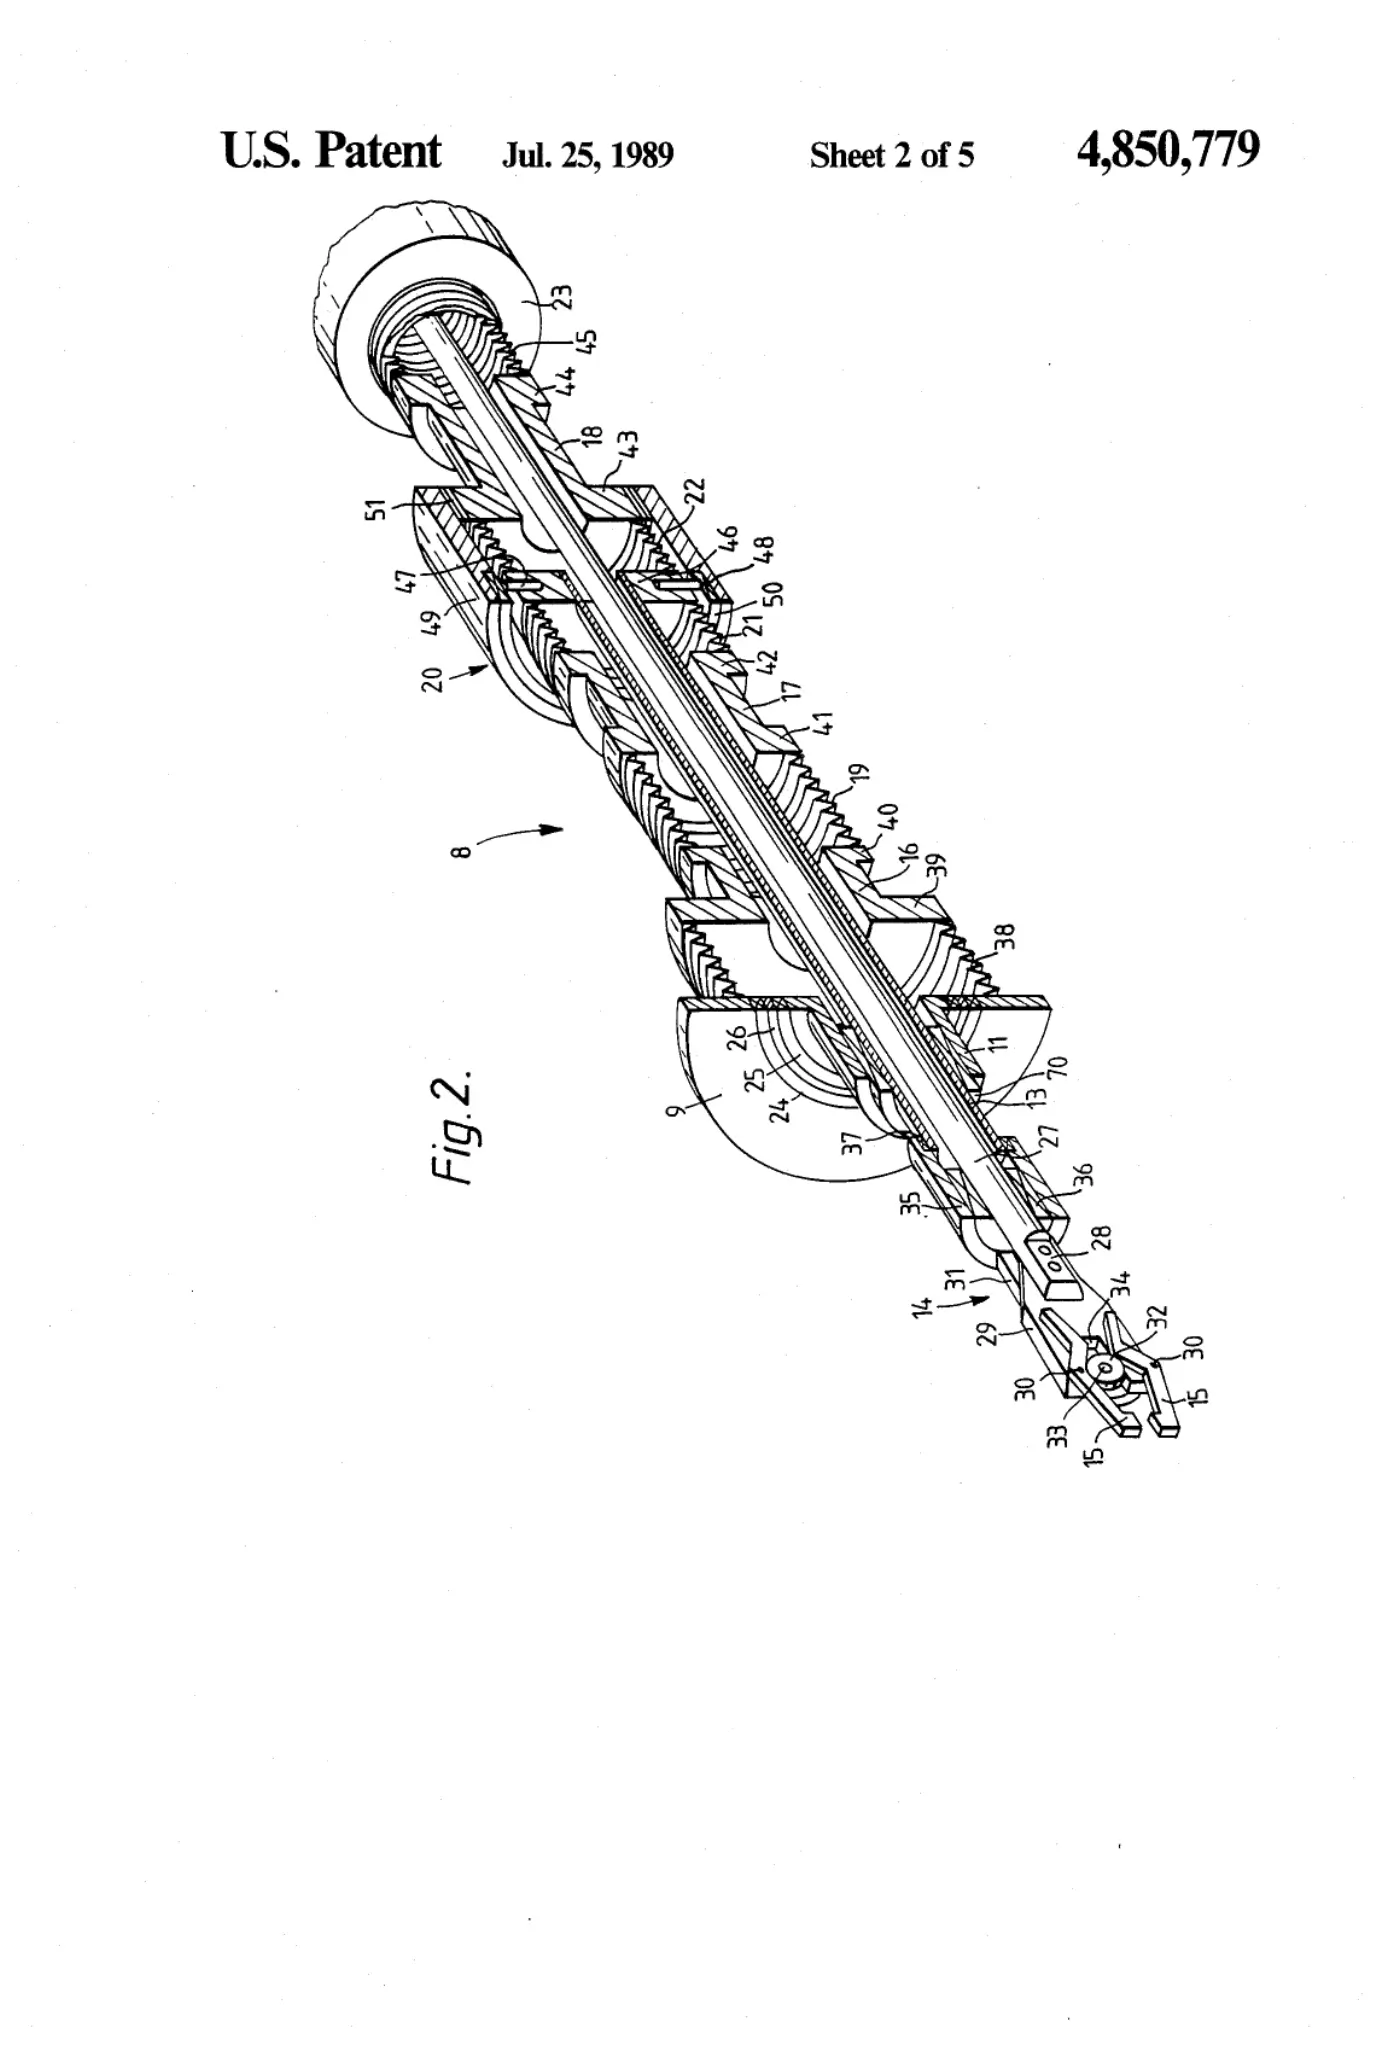
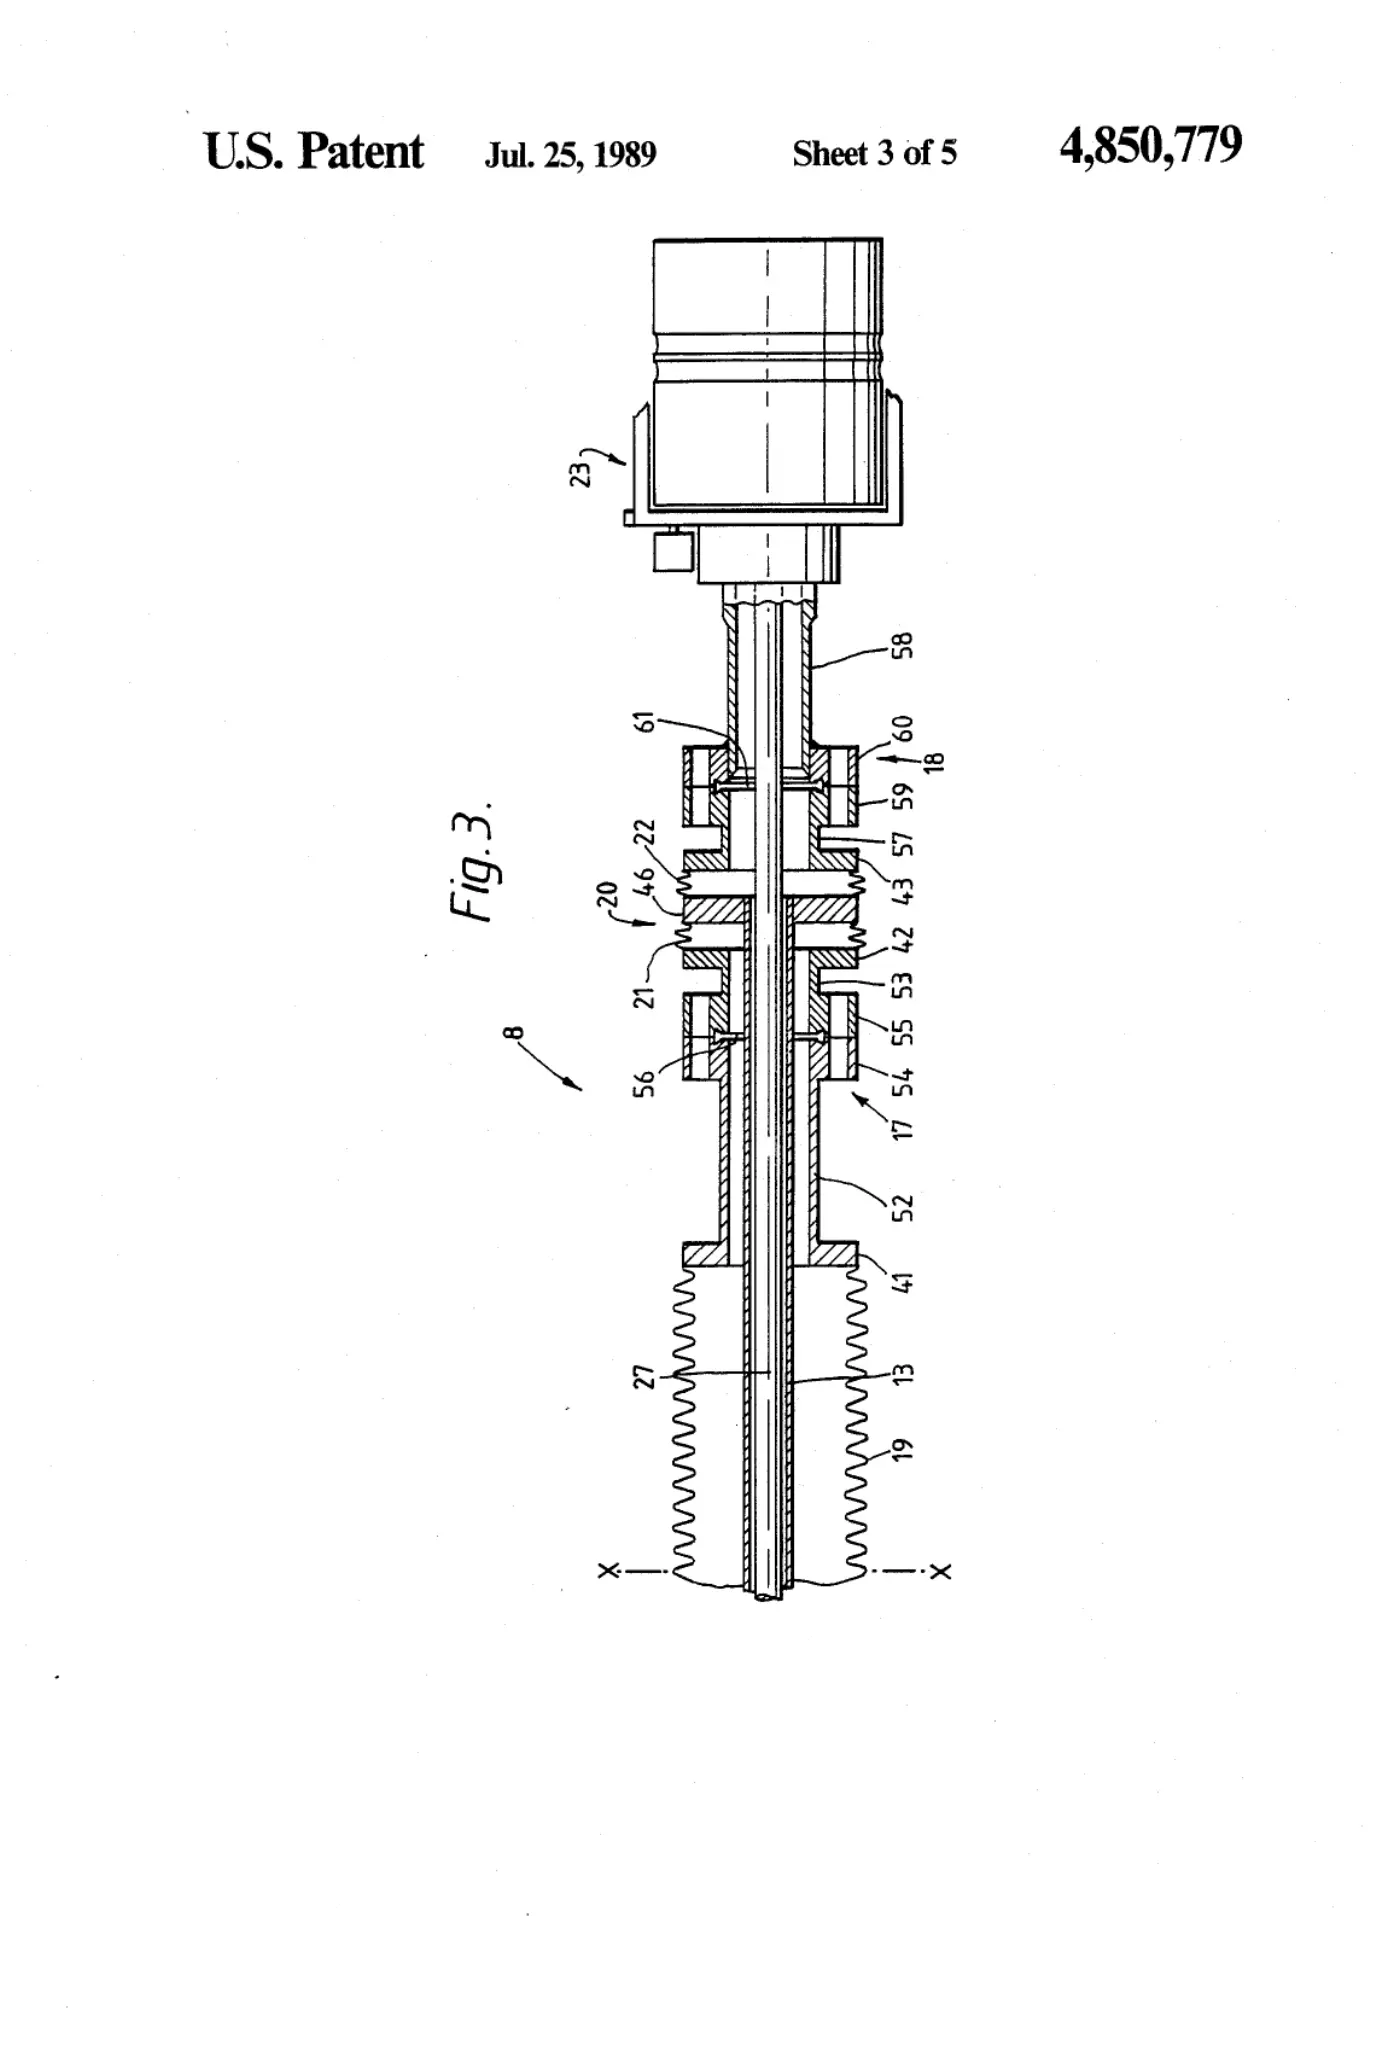
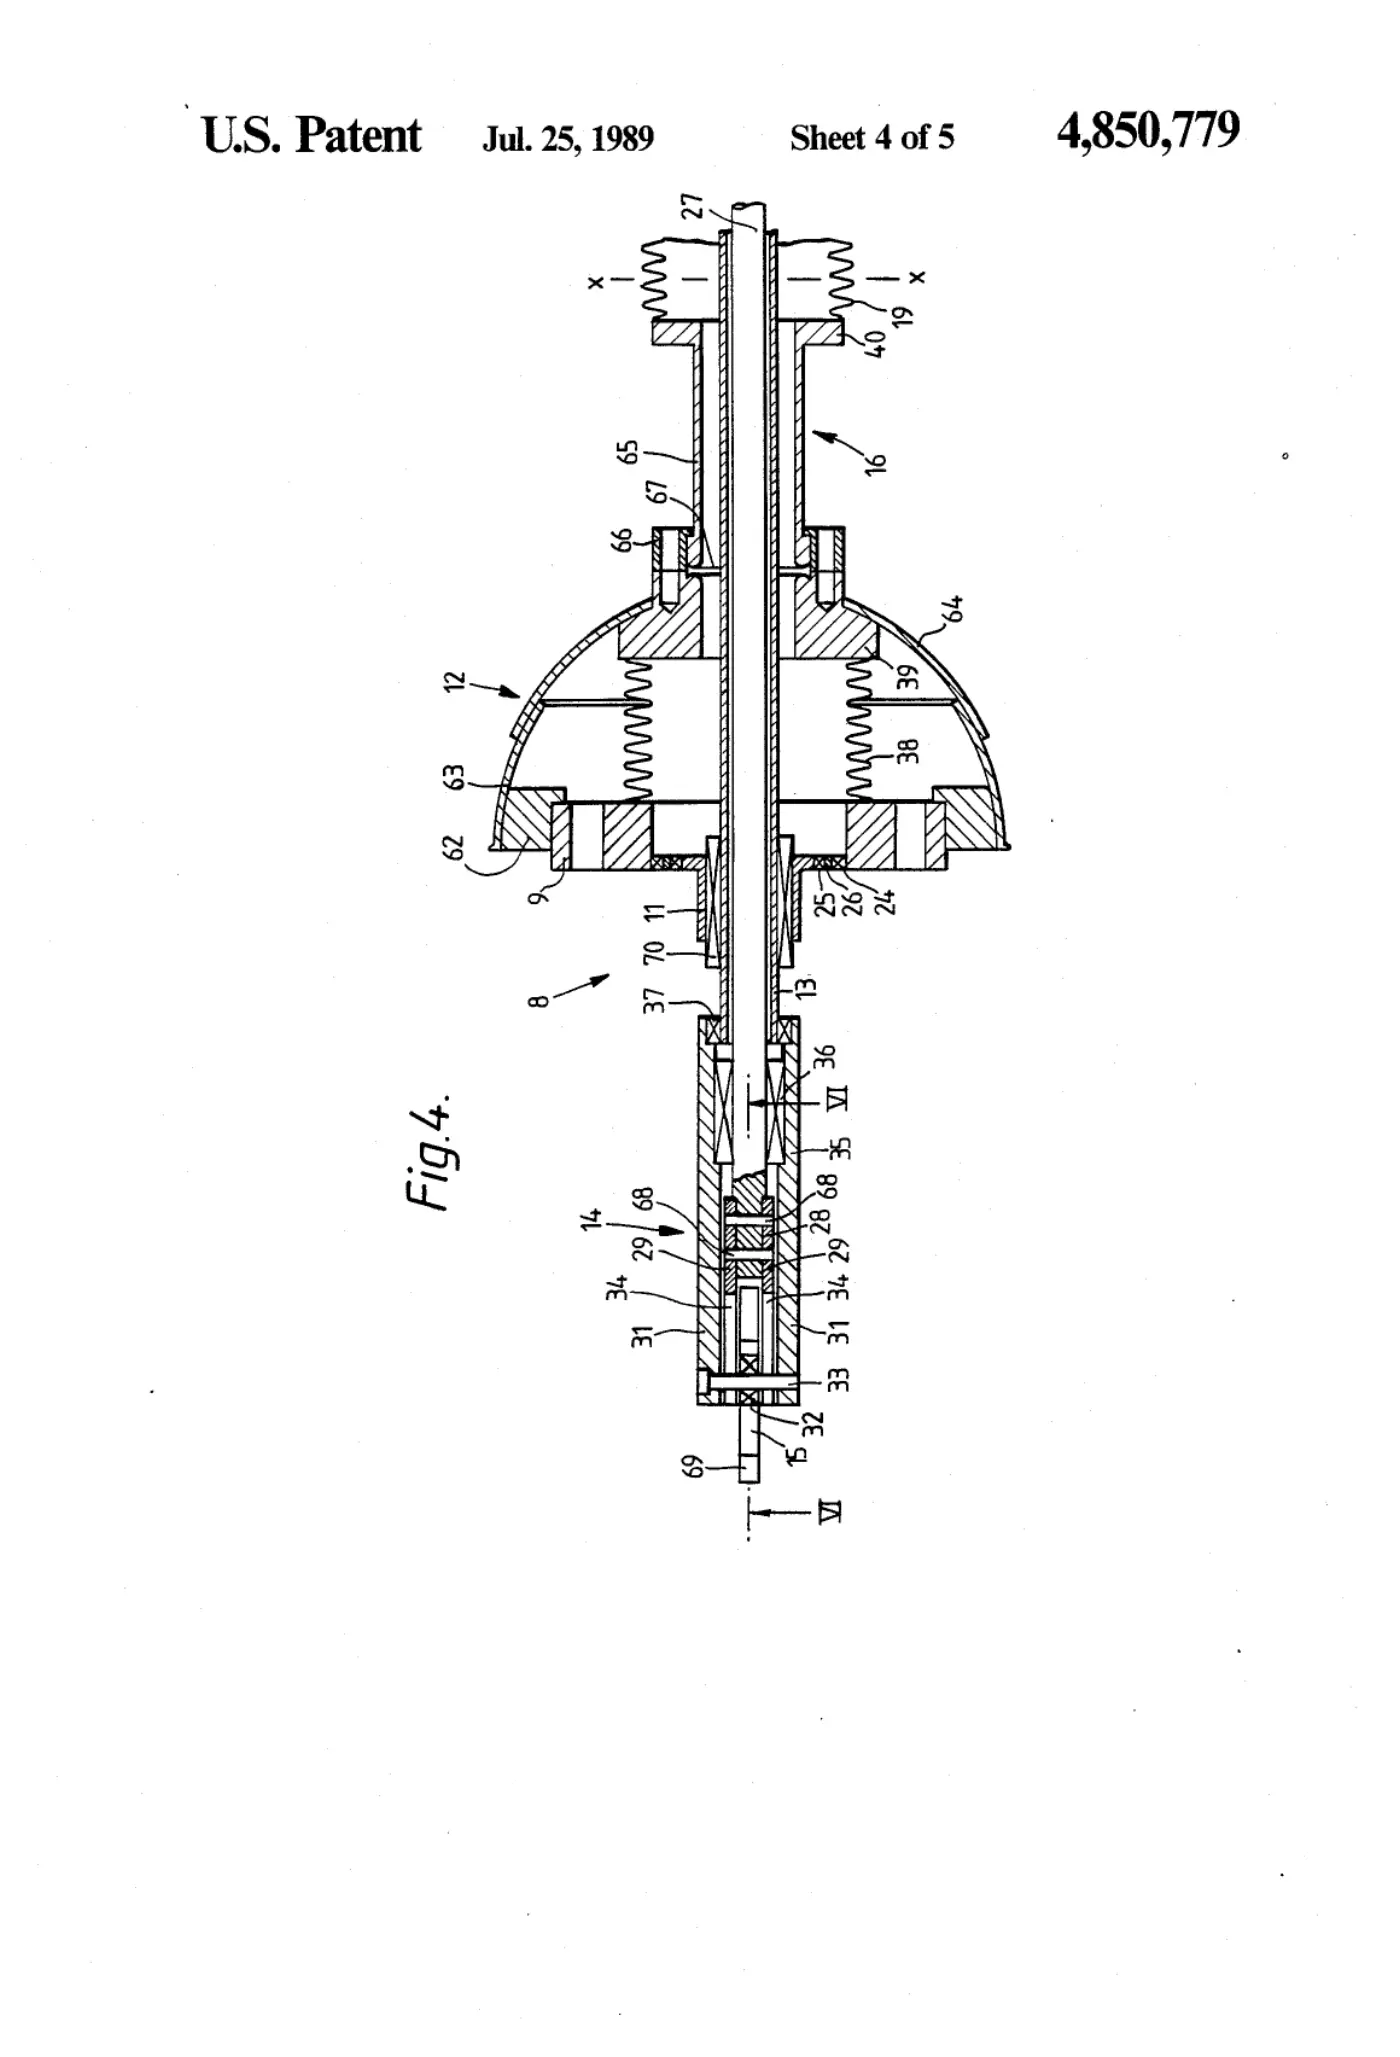
A manipulator for handling objects within a sealed environment, such as an ultra-high vacuum chamber, is mounted on a port of the chamber so that an active portion of the manipulator terminating in a set of gripping jaws is located within the chamber, while an operating portion of the manipulator is located externally of the chamber. The gripping jaws are mounted at one extremity of a shaft for rotation through at least 360° irrespective of whether they are in an open or closed configuration. The jaws are opened and closed from the exterior of the chamber by means of a sleeve which is axially slidable on the shaft by means of a drive ring located on the operating portion of the manipulator. The interior of the manipulator is sealed against the environment external of both the manipulator and the chamber on which it is mounted by a continuous sealing boundary, which has no sliding seals and is made up of a series of rigid sections interconnected by metal bellows units, these latter permitting the rotation and axial shaft and sleeve displacements required for jaw rotation and for opening and closing movements of the jaws. Further metal bellows units in this continuous boundary permit axial displacement of the jaw region of the manipulator, irrespective of its rotational disposition and gripping configuration, and lateral movement of the jaw region in any direction, so that the jaws may be located at any point within a three-dimensional volume determined by the dimensions of the manipulator and the maximum displacements of the bellows units.
Abstract
A manipulator for handling objects within a sealed environment, such as an ultra-high vacuum chamber, is mounted on a port of the chamber so that an active portion of the manipulator terminating in a set of gripping jaws is located within the chamber, while an operating portion of the manipulator is located externally of the chamber. The gripping jaws are mounted at one extremity of a shaft for rotation through at least 360° irrespective of whether they are in an open or closed configuration. The jaws are opened and closed from the exterior of the chamber by means of a sleeve which is axially slidable on the shaft by means of a drive ring located on the operating portion of the manipulator. The interior of the manipulator is sealed against the environment external of both the manipulator and the chamber on which it is mounted by a continuous sealing boundary, which has no sliding seals and is made up of a series of rigid sections interconnected by metal bellows units, these latter permitting the rotation and axial shaft and sleeve displacements required for jaw rotation and for opening and closing movements of the jaws. Further metal bellows units in this continuous boundary permit axial displacement of the jaw region of the manipulator, irrespective of its rotational disposition and gripping configuration, and lateral movement of the jaw region in any direction, so that the jaws may be located at any point within a three-dimensional volume determined by the dimensions of the manipulator and the maximum displacements of the bellows units.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
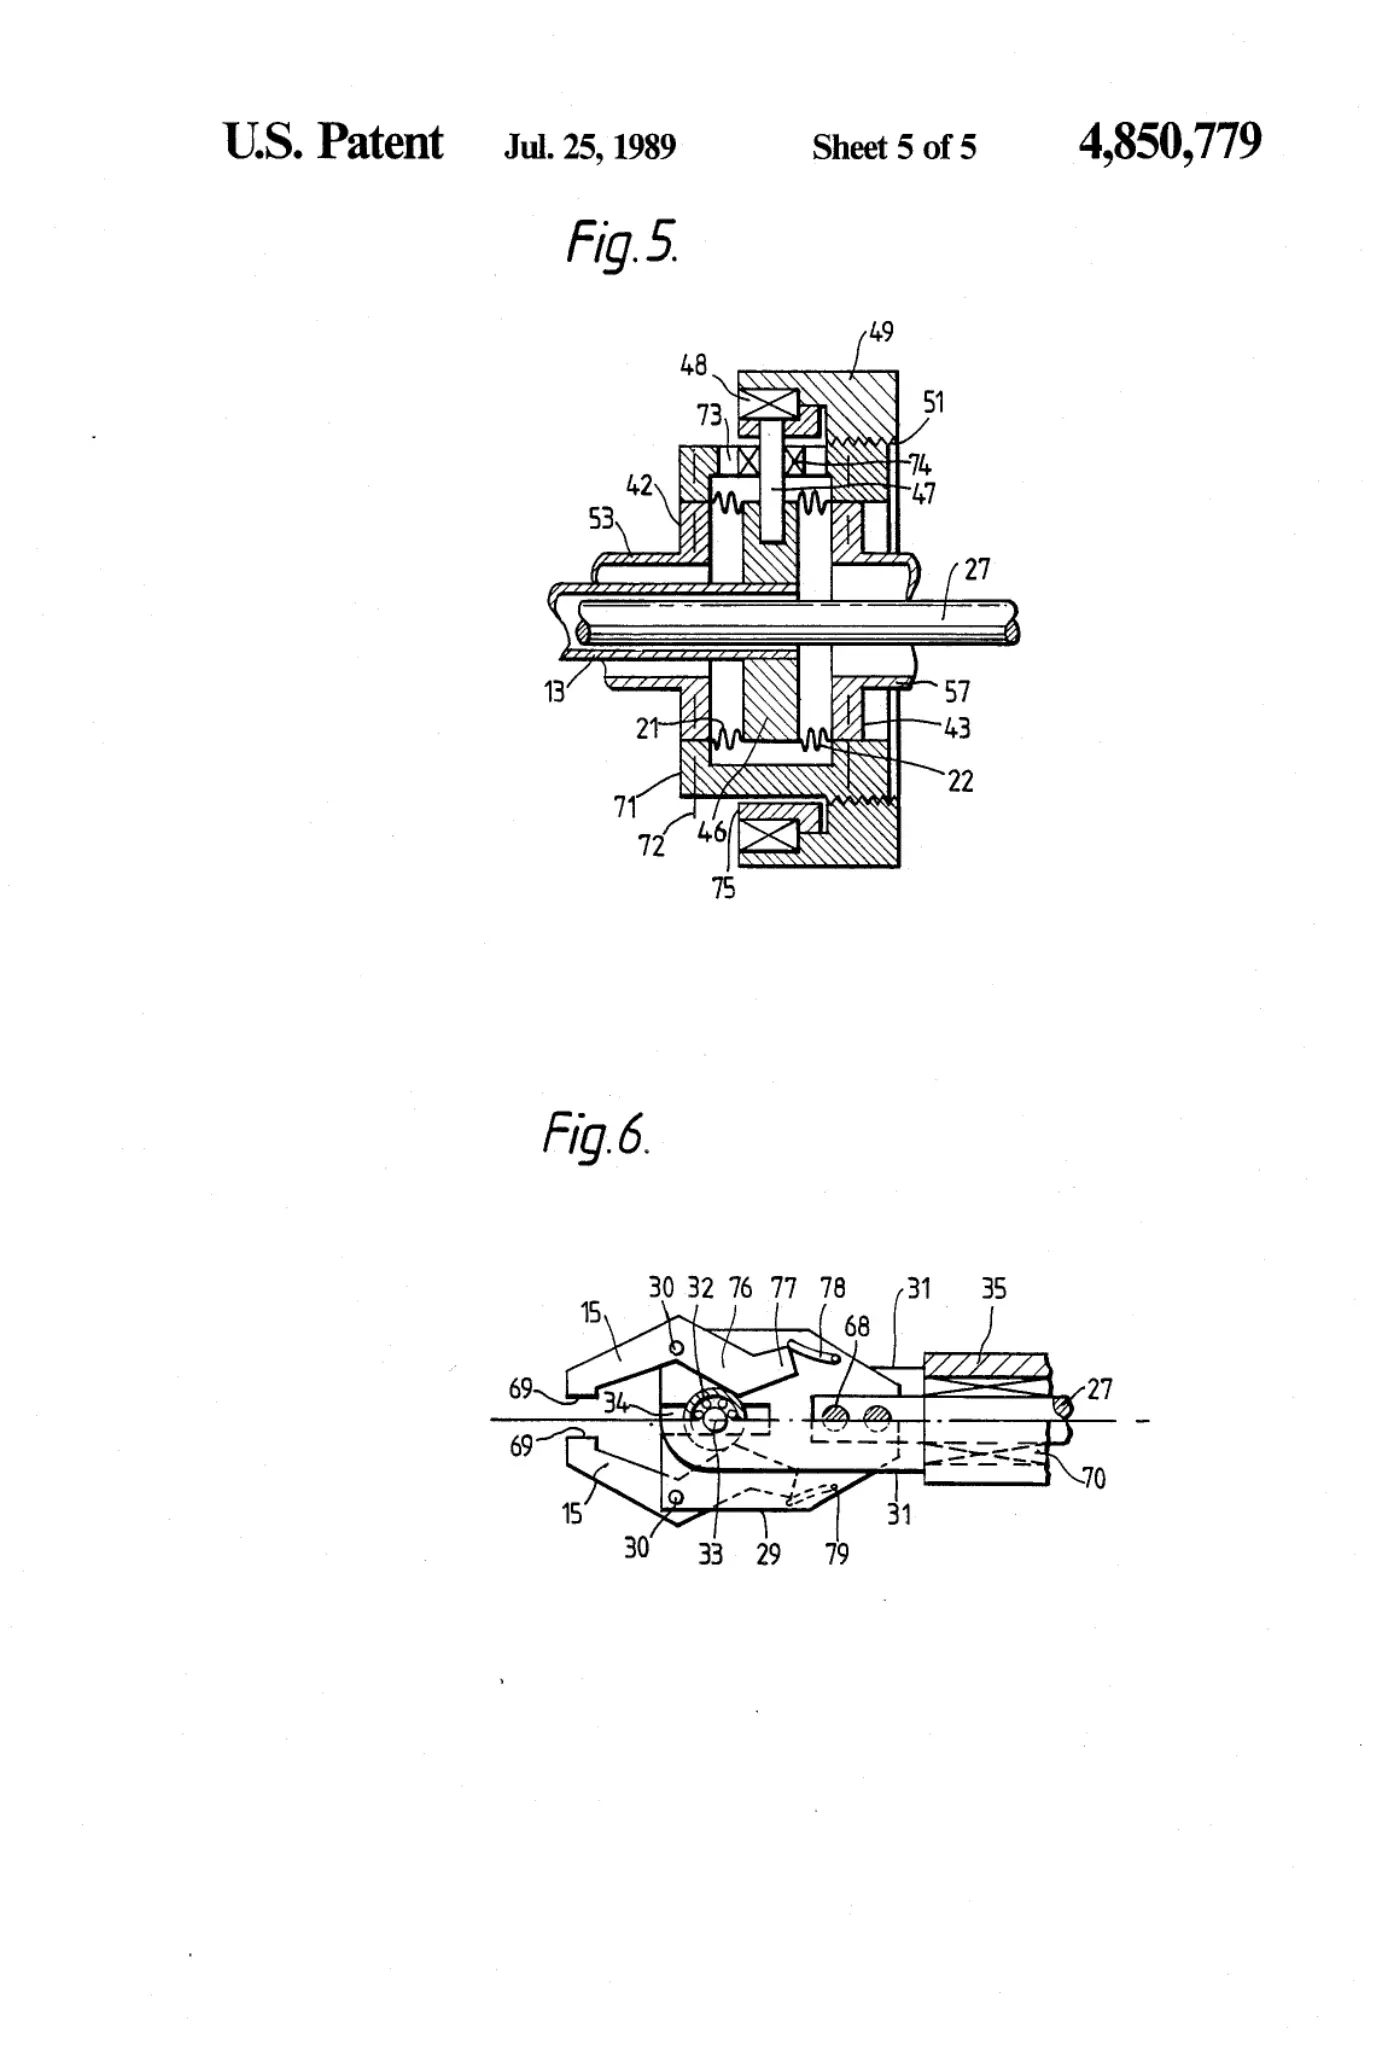
[0005]Sheet 5.
Publication information
Citation
OpenTechnical Publication OT-2026-000003479, “Manipulator for handling objects within a sealed chamber,” published September 15, 2026 at 20:32:49 UTC, https://opentechnical.org/p/OT-2026-000003479.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.