OT-2026-000003485
Vacuum adsorption hand
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003485
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- KIMURA MINAO, NO SHINICHIRO
- Assignee
- YAKULT HONSHA KK
- Original source
- US-4828304-A, the United States Patent and Trademark Office, 9 May 1989
- Document SHA-256
- 9c26df21ff3ae4aa2d9f7d99f6c0f073bd994a1288d9e96522ccb1bab5c00b65
A vacuum adsorption hand and a composite hand mechanism attachable to the arm or the like of a material handling industrial robot are disclosed. The vacuum adsorption hand includes a sponge-like element on the outer surface of a perforated plate defining a vacuum chamber to prevent the ports or perforations in the plate from being obstructed by packaging film on an article to be handled. The composite hand mechanism of the present invention includes grasping mechanisms for grasping the sides of an article to be held in addition to an adsorbing mechanism. The grasping mechanisms have first members adapted for transverse movement to apply an adjustable transverse grasping force and second members which are vertically movable with respect to the first members. The grasping mechanisms ensure that the article will be held securely despite the effects of horizontally-oriented forces acting on the article held by the composite hand mechanism.
Abstract
A vacuum adsorption hand and a composite hand mechanism attachable to the arm or the like of a material handling industrial robot are disclosed. The vacuum adsorption hand includes a sponge-like element on the outer surface of a perforated plate defining a vacuum chamber to prevent the ports or perforations in the plate from being obstructed by packaging film on an article to be handled. The composite hand mechanism of the present invention includes grasping mechanisms for grasping the sides of an article to be held in addition to an adsorbing mechanism. The grasping mechanisms have first members adapted for transverse movement to apply an adjustable transverse grasping force and second members which are vertically movable with respect to the first members. The grasping mechanisms ensure that the article will be held securely despite the effects of horizontally-oriented forces acting on the article held by the composite hand mechanism.
1. Drawings
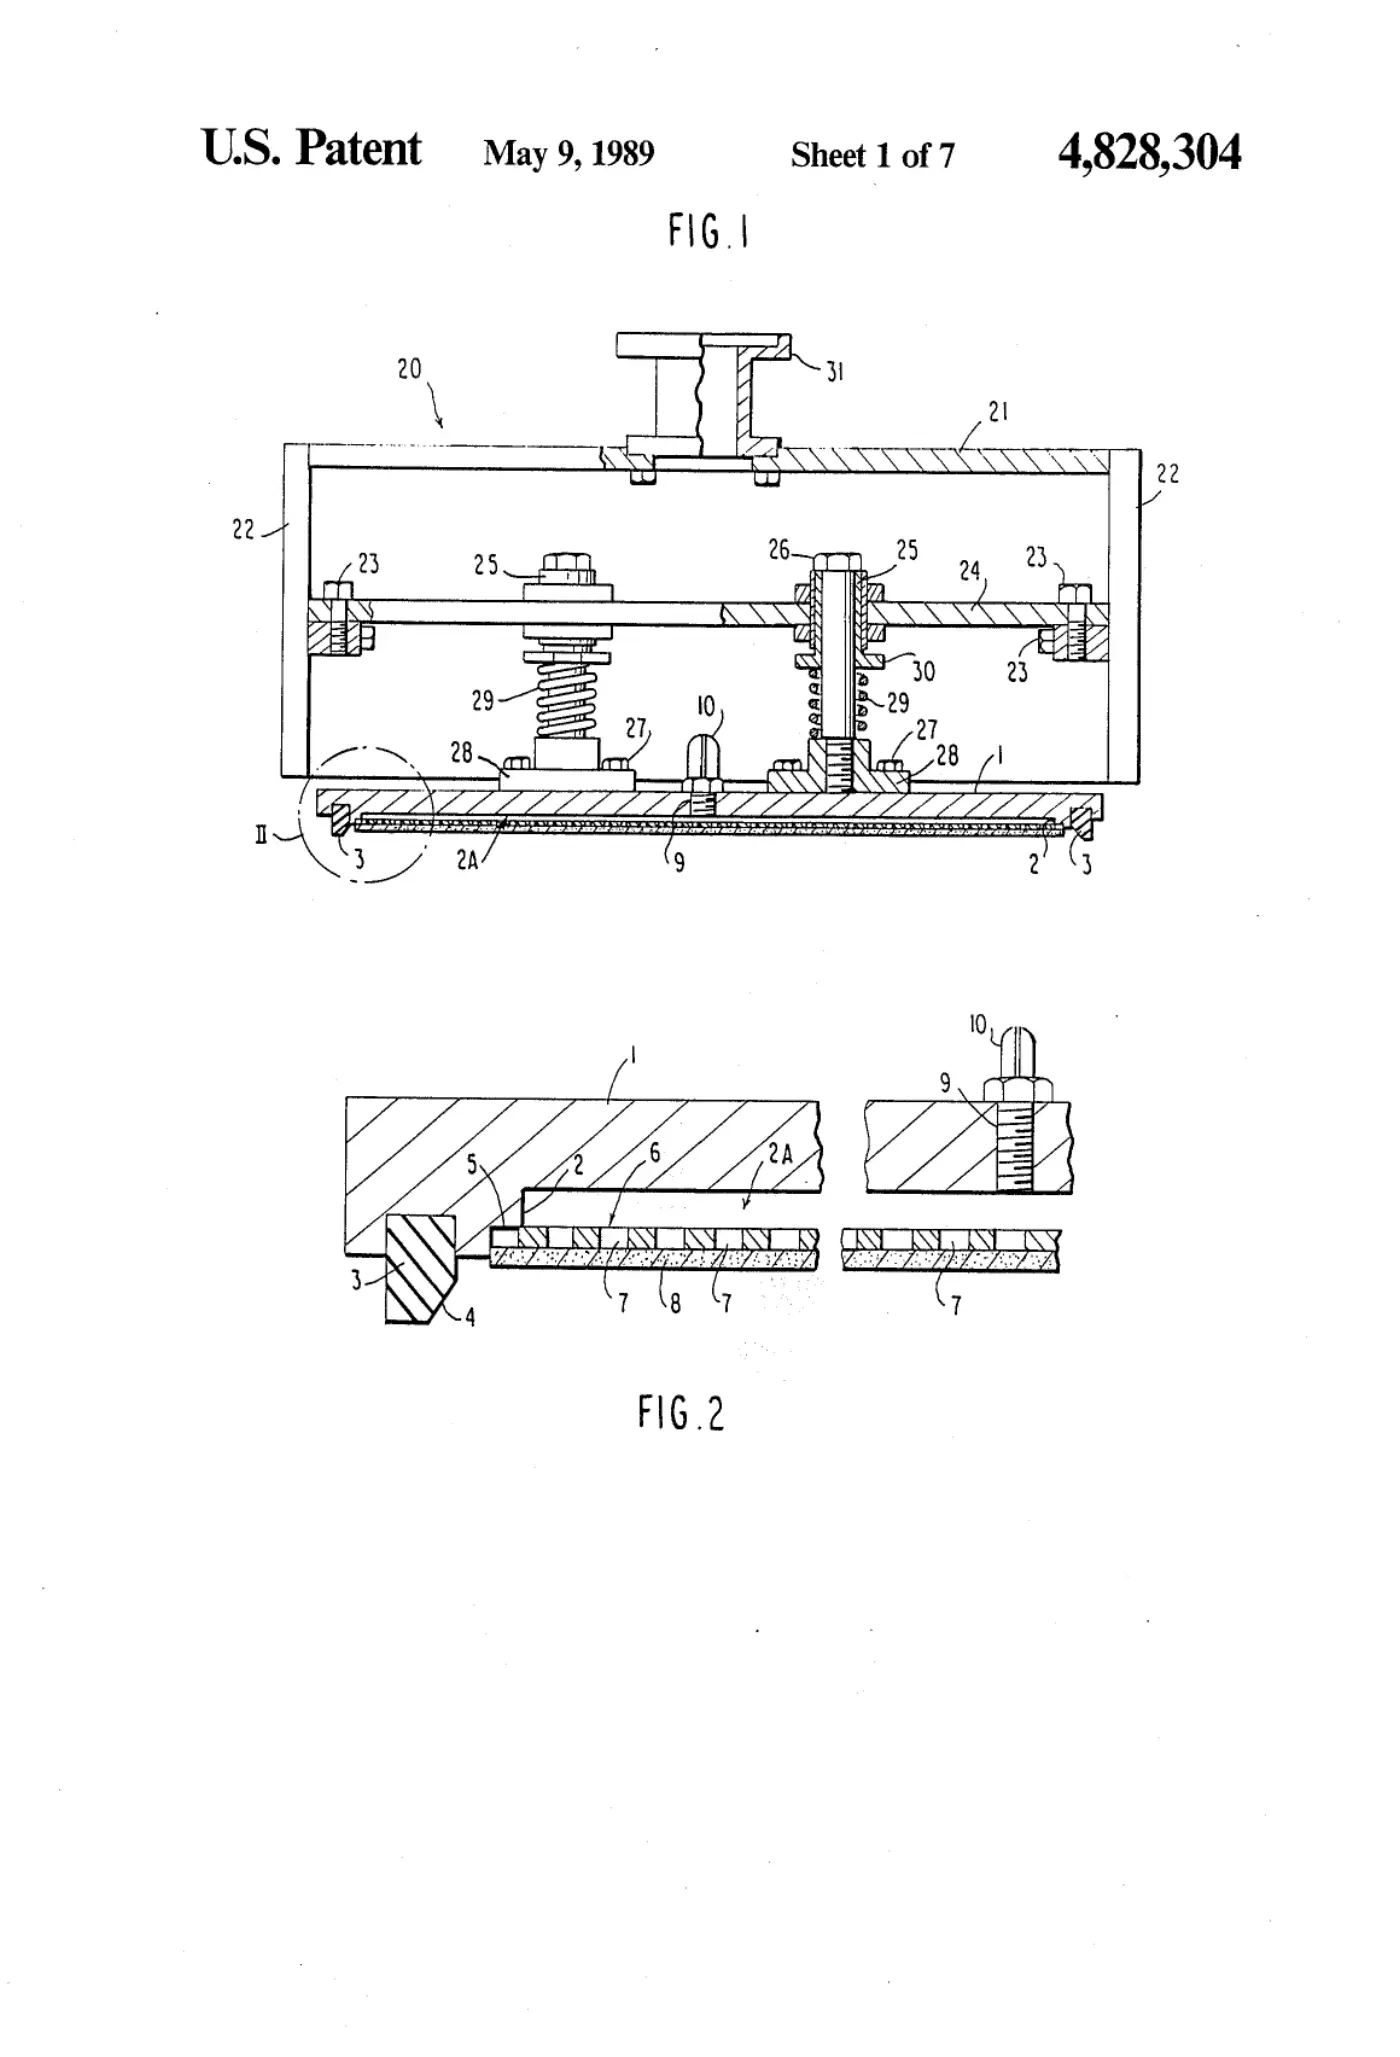
[0001]Sheet 1.
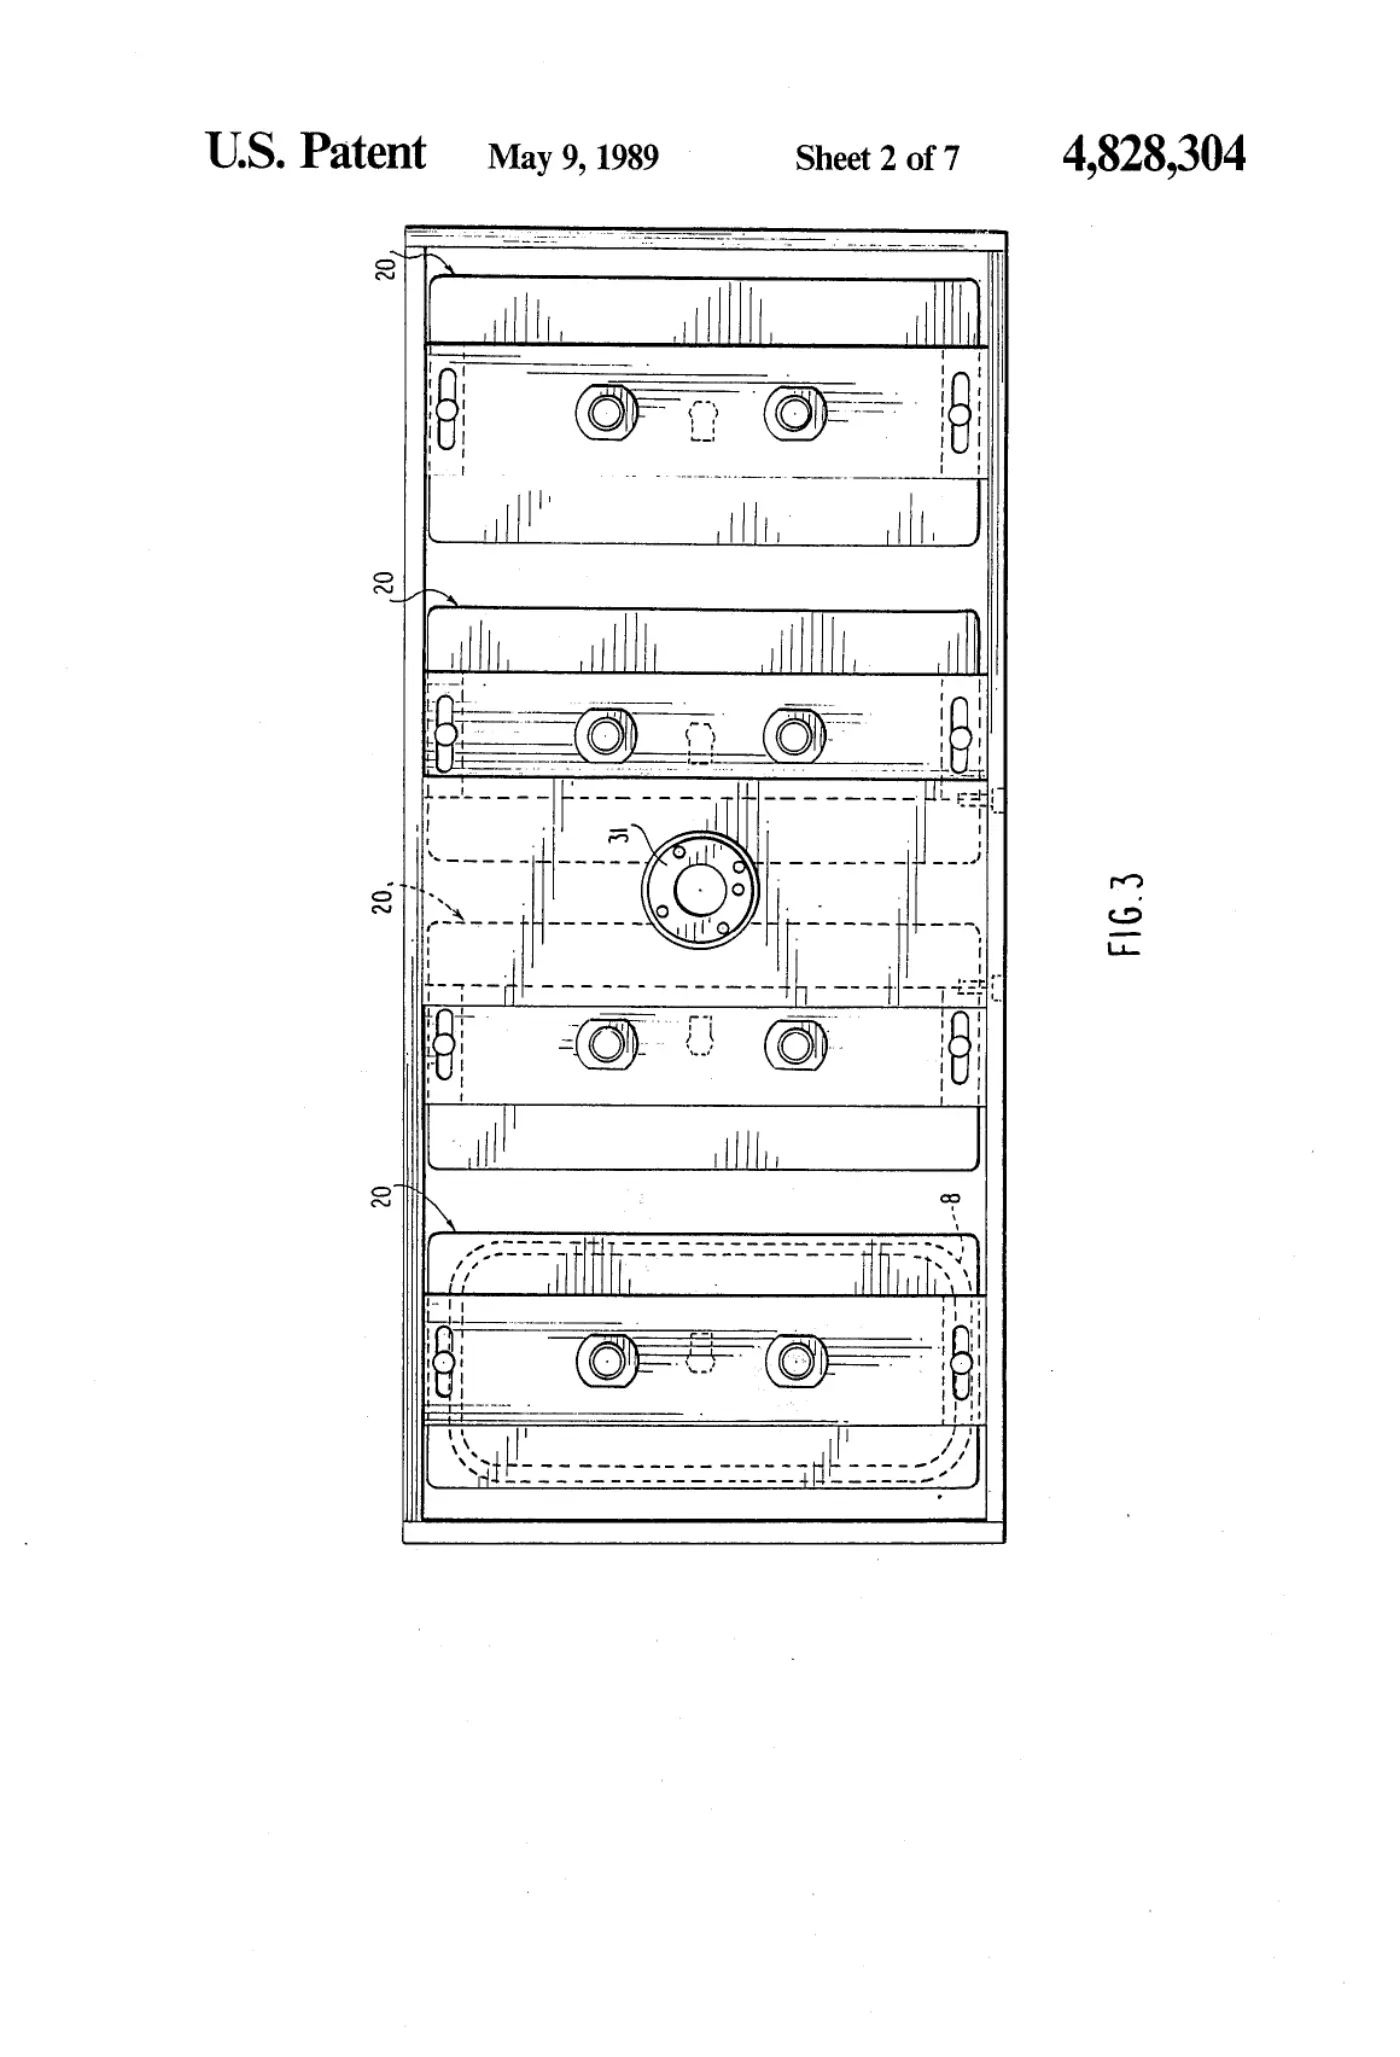
[0002]Sheet 2.
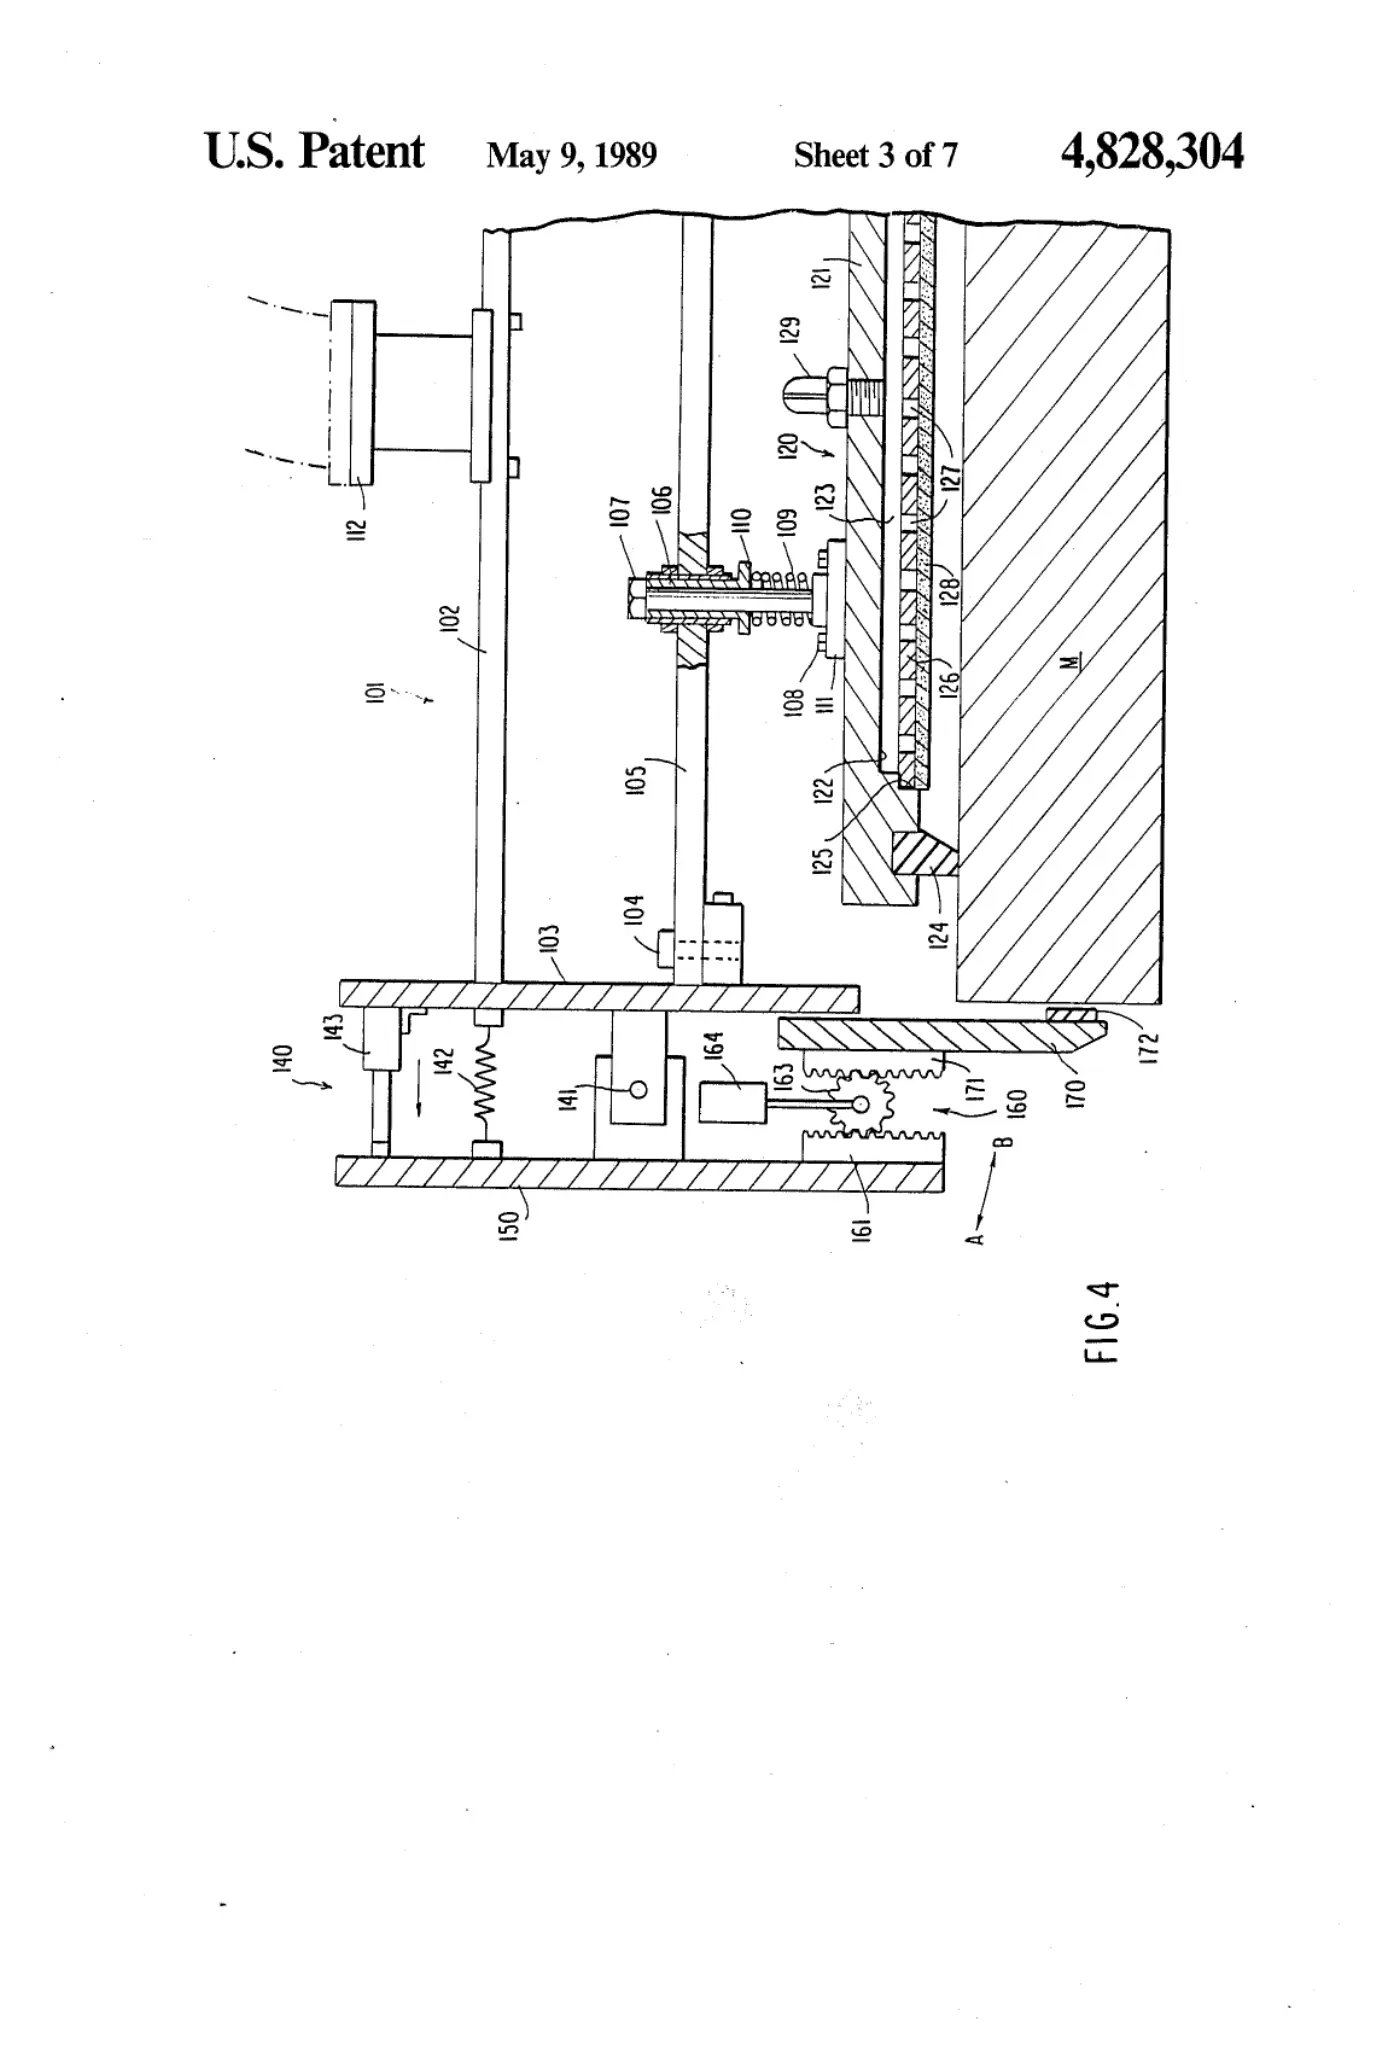
[0003]Sheet 3.
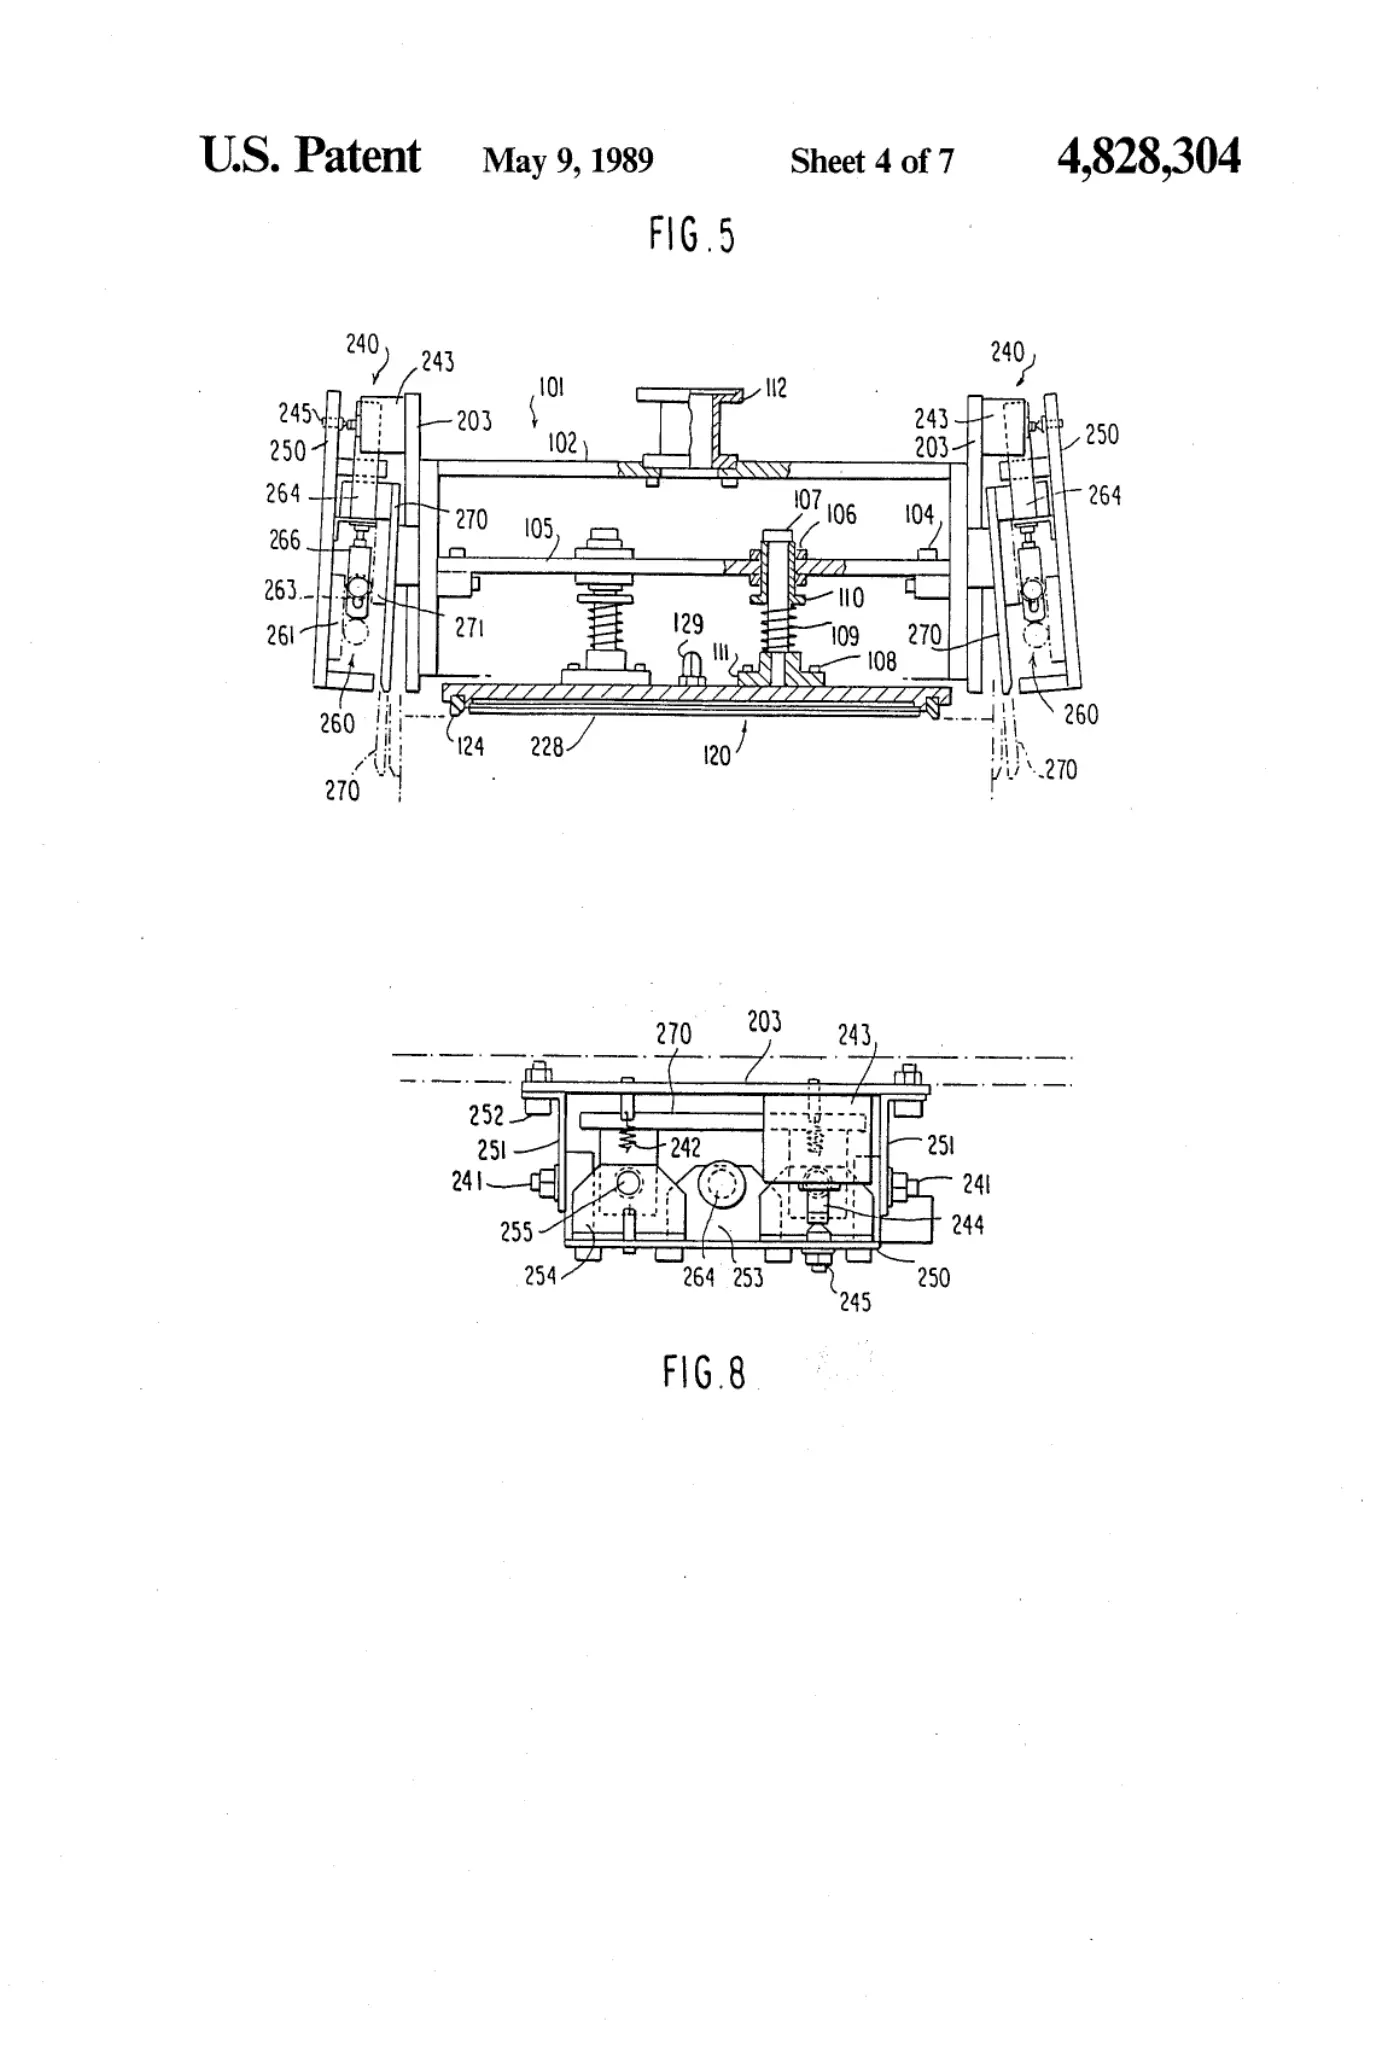
[0004]Sheet 4.
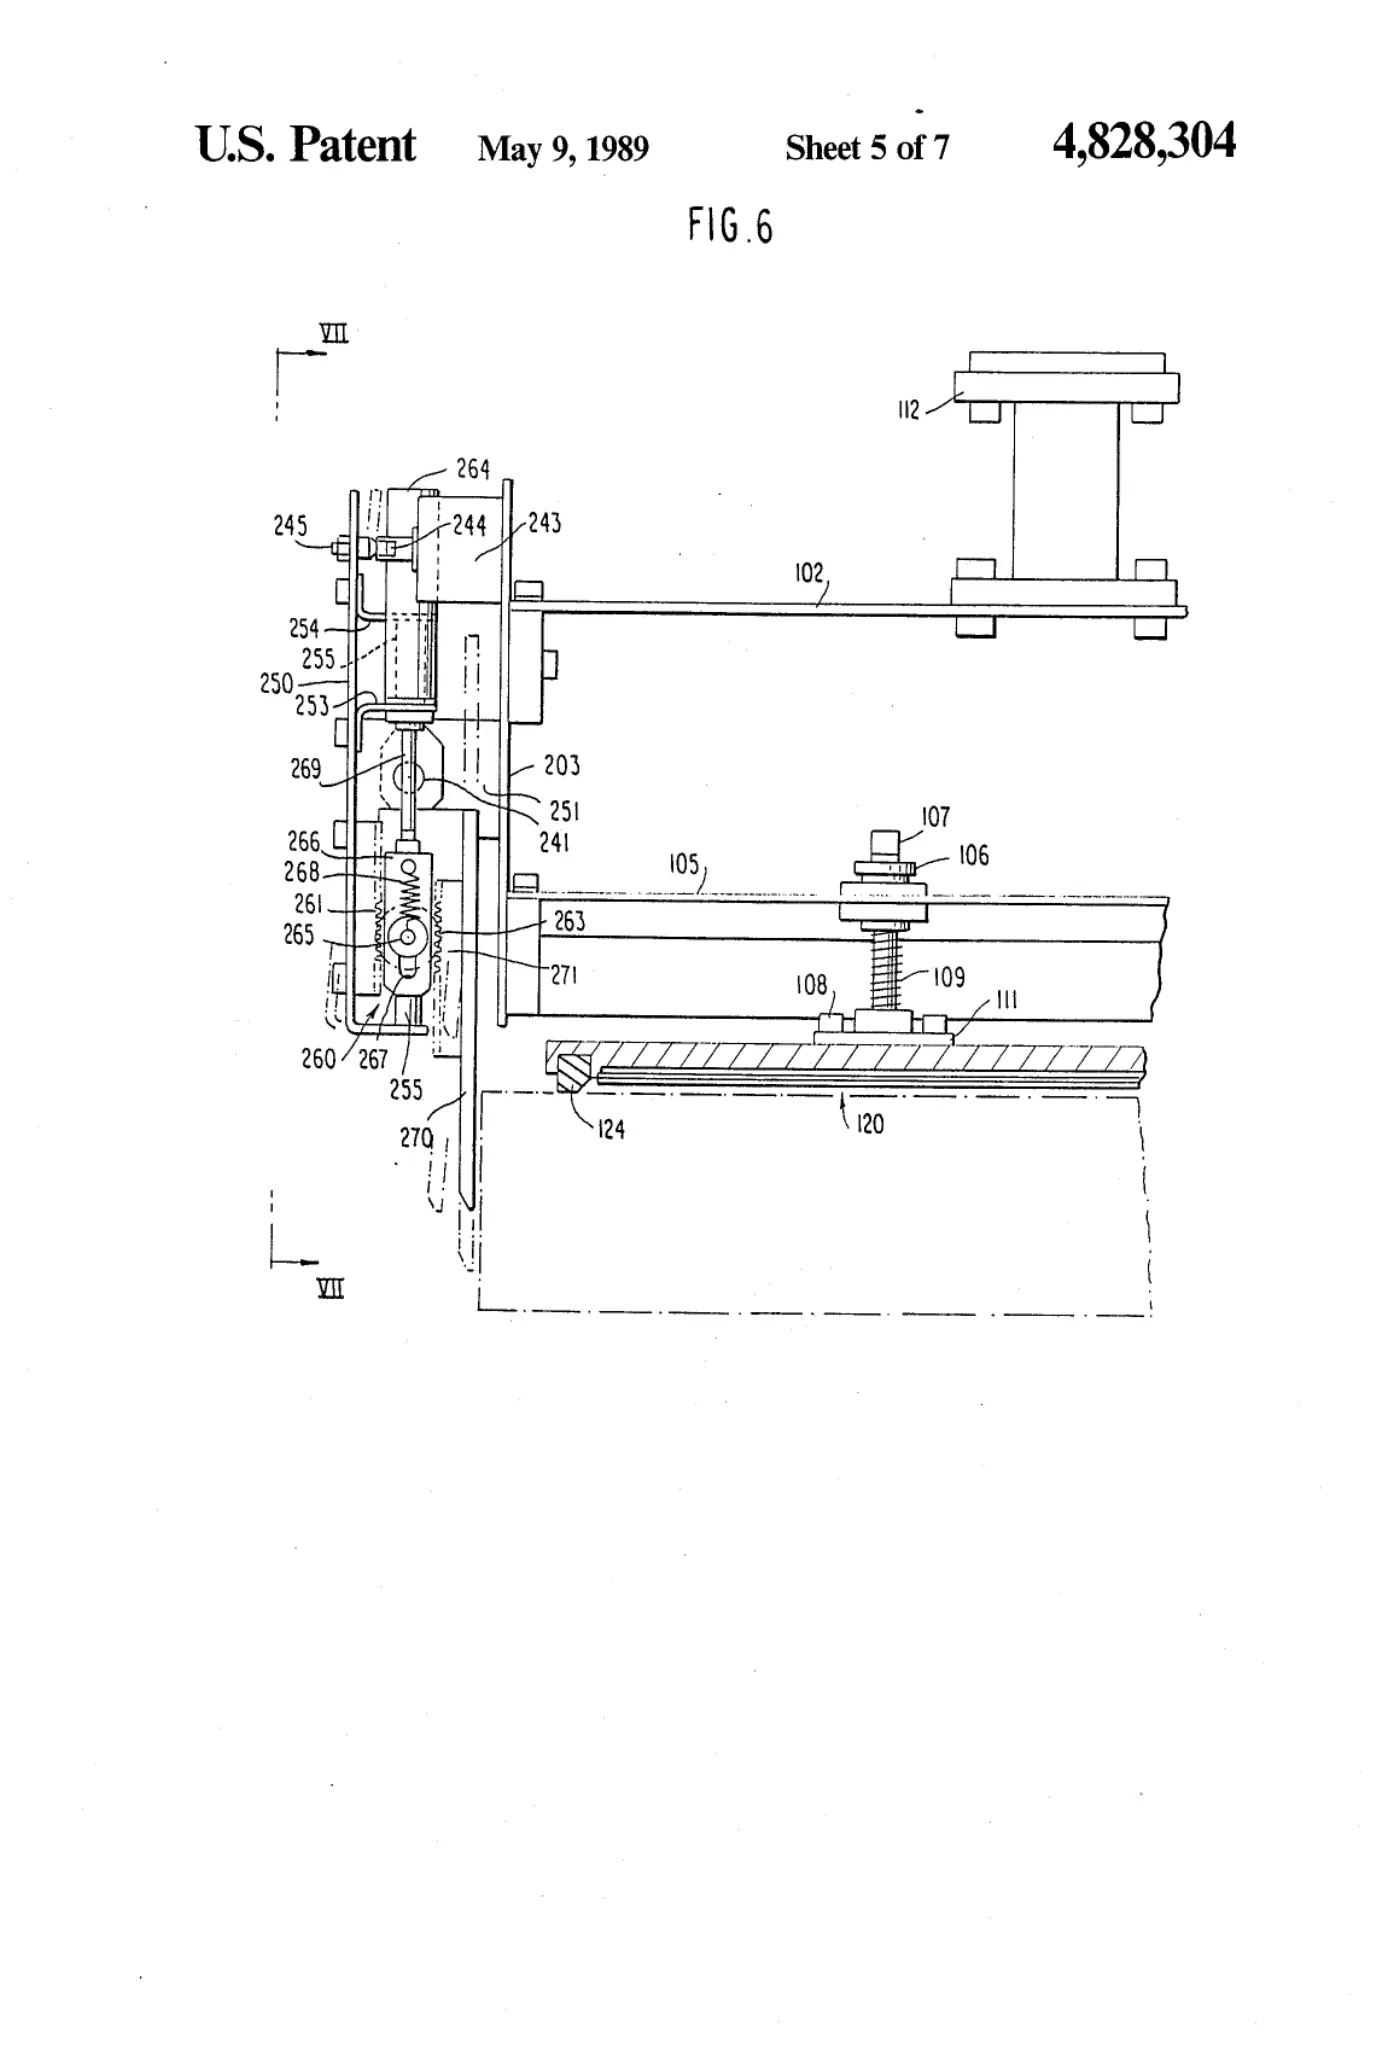
[0005]Sheet 5.
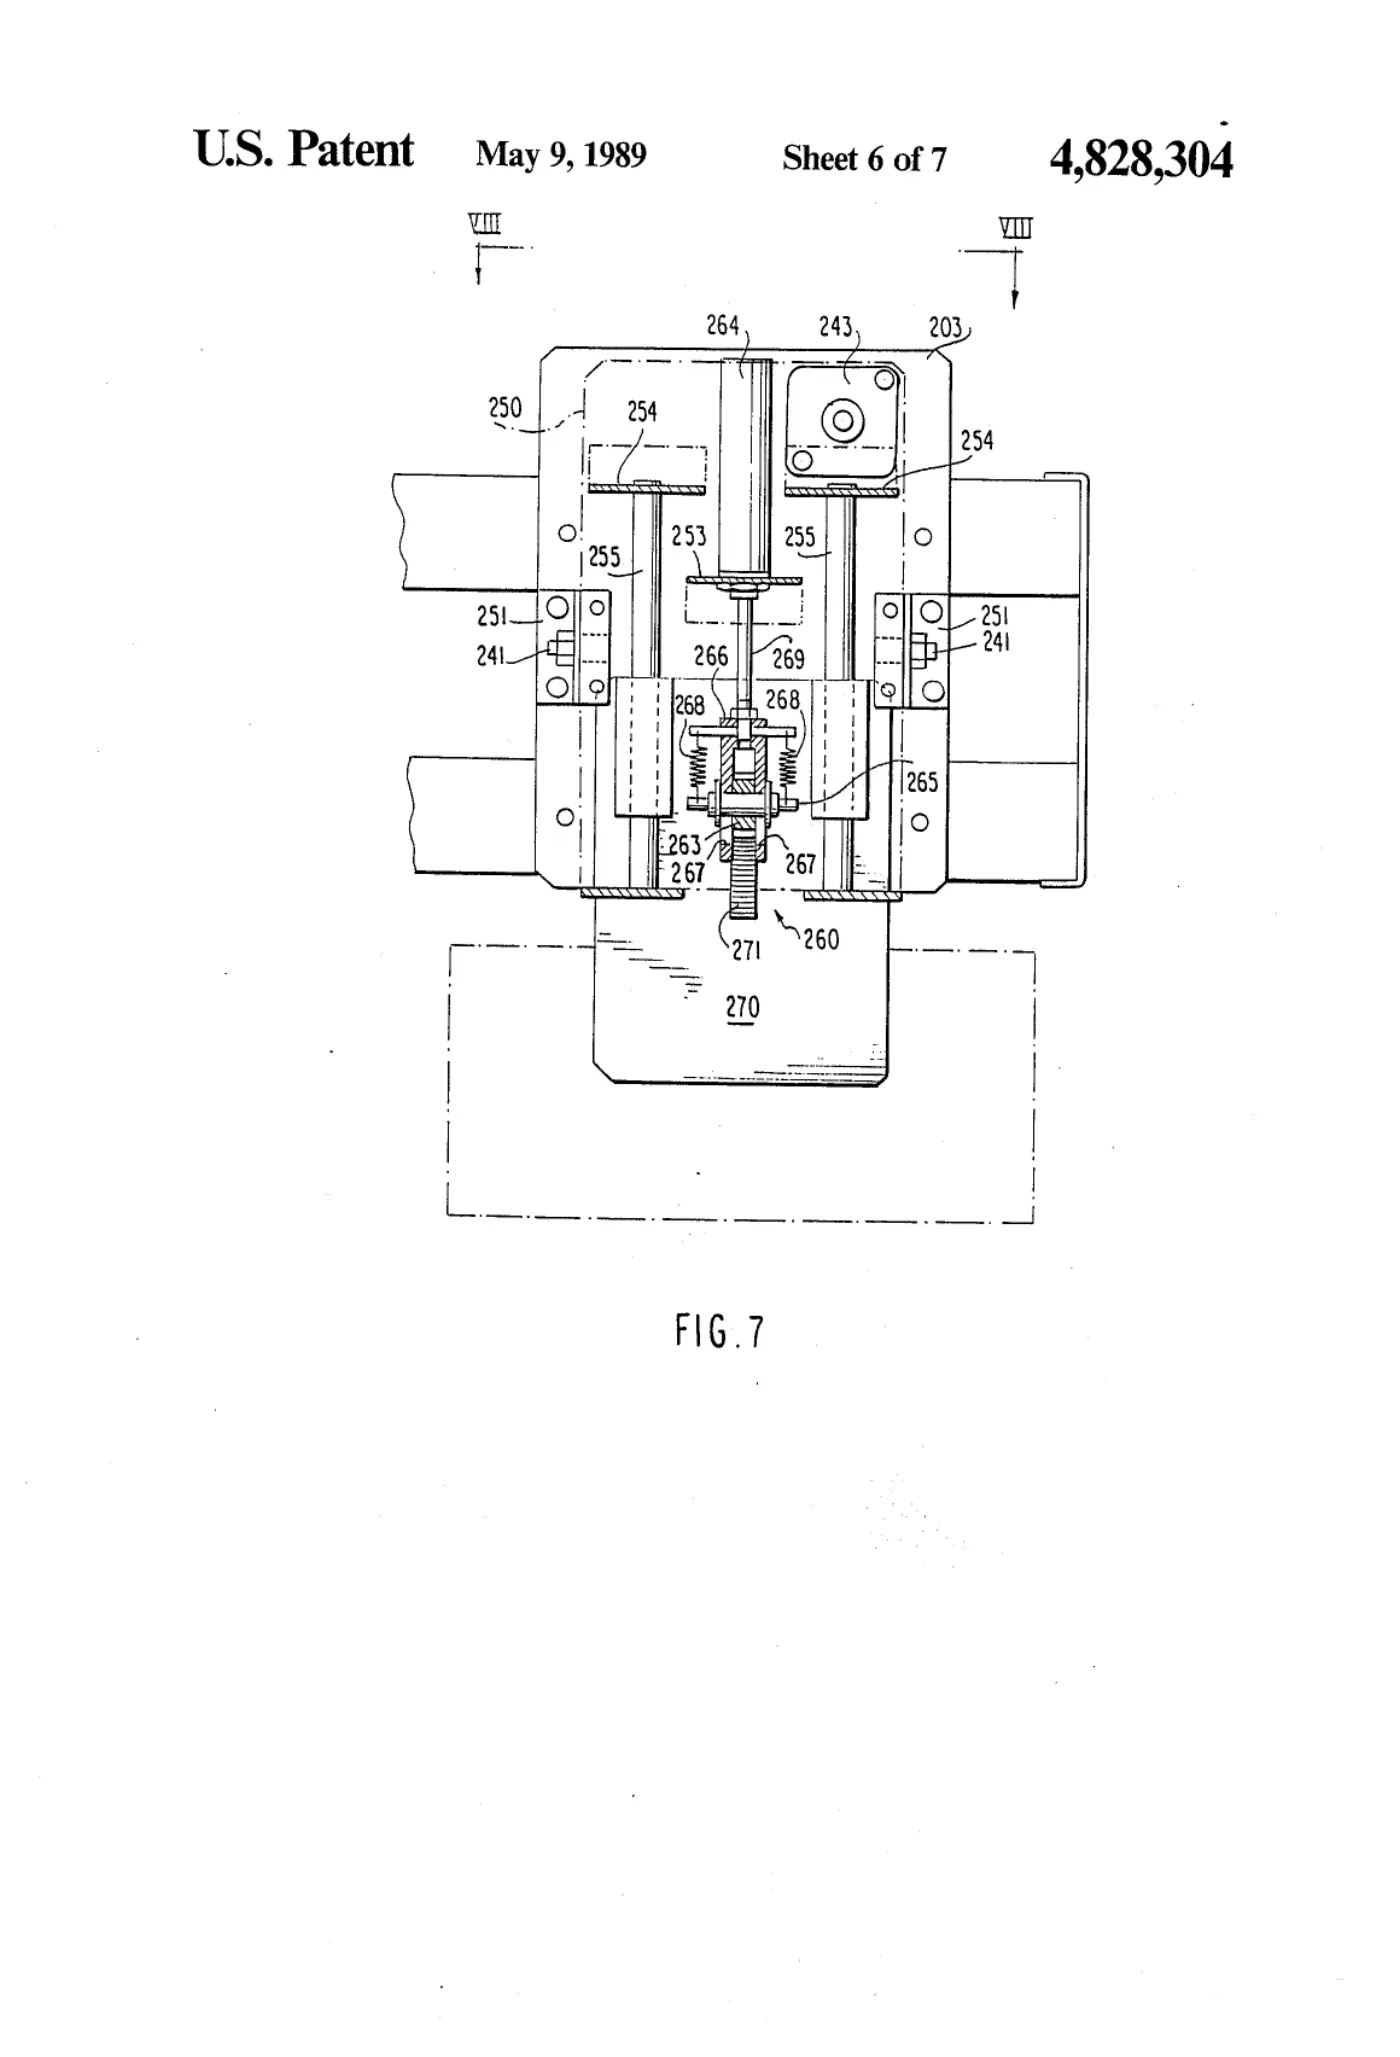
[0006]Sheet 6.
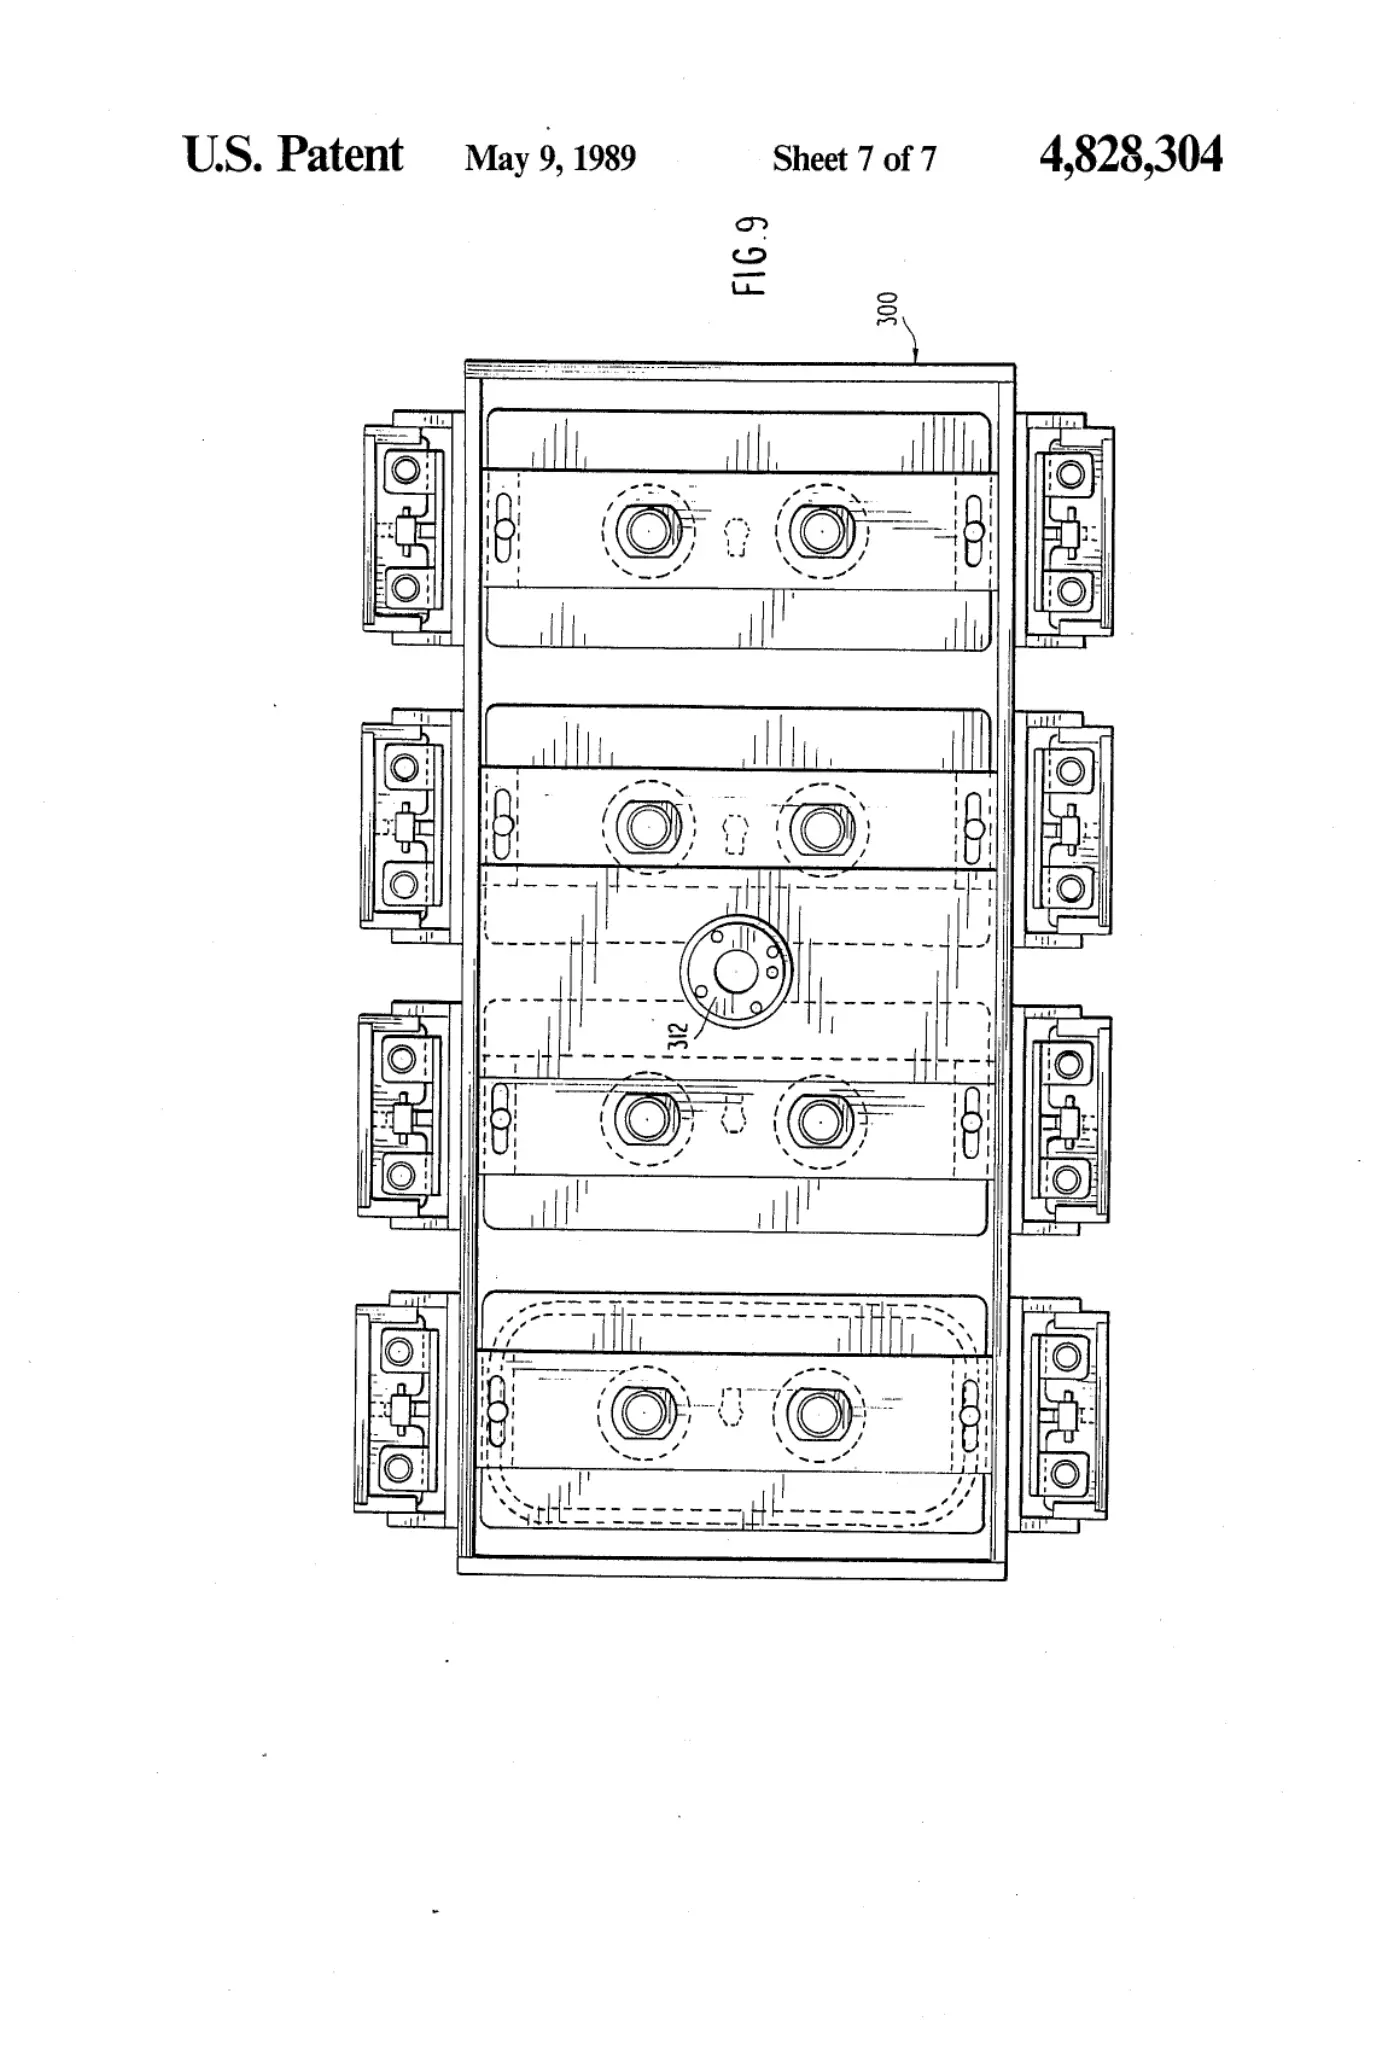
[0007]Sheet 7.
Publication information
Citation
OpenTechnical Publication OT-2026-000003485, “Vacuum adsorption hand,” published September 15, 2026 at 20:33:44 UTC, https://opentechnical.org/p/OT-2026-000003485.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.