Abstract
An end effector for vacuum end-of-arm tooling with compliant bellows cups is described. The tool comprises a mounting flange (10), a bellows cup (12), a ejector (14), a isolation valve (16), a zone branch (18), and a contact detector (20), a vent valve (22). The arrangement addresses handling workpieces that do not cover the whole gripping face, where an uncovered suction cup is an open leak, and one open leak pulls the whole circuit towards atmosphere, so a tool sized for the largest workpiece loses grip on the smallest. The description covers which part of the circuit is cut, what keeps its own vacuum while the cut is made, and what the remaining zones do while one zone is isolated. Every connection is stated with the medium it carries, and the operating sequence is given as conditions on named operations.
1. Technical Field
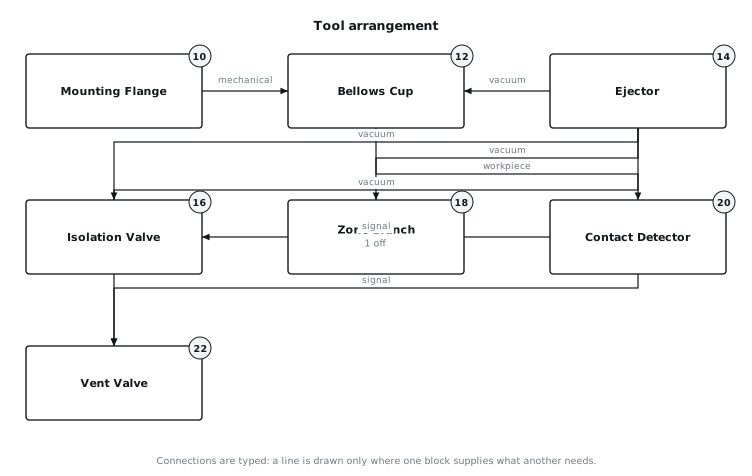
[0001]This disclosure relates to vacuum end-of-arm tooling with compliant bellows cups. It concerns the arrangement of a gripping interface, the supply that feeds it, the distribution and control between them, and the sequence in which those parts act on a workpiece. FIG. 1 shows the arrangement as a block diagram with the reference numerals used throughout this description.
2. Technical Context
[0002]The arrangement addresses handling workpieces that do not cover the whole gripping face. The difficulty is that an uncovered suction cup is an open leak, and one open leak pulls the whole circuit towards atmosphere, so a tool sized for the largest workpiece loses grip on the smallest. A tool that does not address it is still usable on a narrow range of workpieces, and the cost appears as cycle time, dropped parts or air consumption rather than as an outright failure. What follows covers which part of the circuit is cut, what keeps its own vacuum while the cut is made, and what the remaining zones do while one zone is isolated.
3. System Overview
[0003]The tool comprises the mounting flange (10), the bellows cup (12), the ejector (14), the isolation valve (16), the zone branch (18), the contact detector (20), the vent valve (22). FIG. 1 shows how these blocks are connected and which medium each connection carries. The blocks are not interchangeable by name: a connection is made only where one block offers a medium that another needs, and each connection below is stated together with the medium it carries.
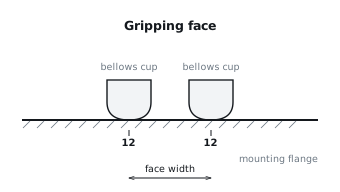
[0004]FIG. 2 shows elevation of the gripping face on its mounting.
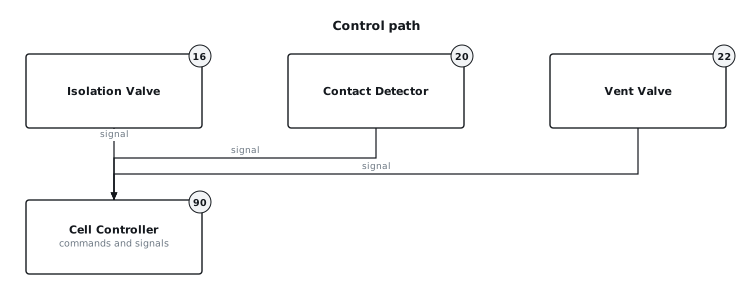
[0005]FIG. 3 shows signal path between the controlled elements and the cell controller.
[0006]
- The mounting flange is bolted to the robot flange (10).
[0007]
- Each bellows cup is connected to the ejector by a vacuum line that runs into the bellows body (12).
[0008]
- Each bellows cup is mounted on the mounting flange (12).
[0009]
- Compressed air is fed to the ejector from the compressed air supply of the cell (14).
[0010]
- The isolation valve is placed in the line from the ejector, so that closing the valve cuts that line and leaves the rest of the circuit under vacuum (16).
[0011]
- The valve is switched by the contact detector (16).
[0012]
- Each zone branch is taken from the ejector, so that the branch carries the vacuum of its own zone only (18).
[0013]
- The detector watches the bellows cups and reports when a workpiece is present at that face (20).
[0014]
- The vent valve is connected to the circuit at the ejector and opens that circuit to atmosphere when it is actuated (22).
[0015]
- The vent valve is switched by the contact detector (22).
4. Components
[0016]Mounting Flange (10). The mounting flange (10) is provided once in this arrangement. The flange carries the whole assembly and presents the bolt pattern that meets the robot.
[0017]Bellows Cup (12). The bellows cup (12) is provided once in this arrangement. Each cup is folded so that it shortens under vacuum and takes up a height difference between the face and the workpiece. Each cup carries 2 folds. The cups are made of plastic.
[0018]Ejector (14). The ejector (14) is provided once in this arrangement. The ejector draws the circuit down by passing compressed air through a nozzle, so it needs no moving part at the tool. The ejector is built with 3 stages.
[0019]Isolation Valve (16). The isolation valve (16) is provided once in this arrangement. The valve sits in the line it controls, so closing it cuts that line without disturbing the rest of the circuit. An isolation valve is provided per zone. The isolation valve (16) is configured with material steel.
[0020]Zone Branch (18). The tool carries 1 zone branches. Each branch feeds one zone of the face, so the zones can be treated separately. The zone branch (18) is configured with material plastic. The face is divided into 2 zones.
[0021]Contact Detector (20). The contact detector (20) is provided once in this arrangement. The detector watches the face and reports the moment a workpiece is present against it. The detector is placed on the frame.
[0022]Vent Valve (22). The vent valve (22) is provided once in this arrangement. The vent valve opens the circuit to atmosphere, which is what ends the grip. The circuit is vented after set-down.
5. Operation
[0023]The operating sequence is given as conditions on named operations. Each condition names the event it depends on and the operation it governs, so the order of events is explicit rather than implied by the order of the sentences. FIG. 2 shows the gripping face referred to in these steps. The tool is presented to the workpiece square to the face, and the numbered operations below are what the arrangement does from that point.
[0024]
- When the bellows cups seal the workpiece, the bellows cups are evacuated by the ejector.
[0025]
- After the contact detector has detected the workpiece, the vacuum supply is actuated.
[0026]
- While the isolation valve is in the closed state, its own vacuum is held by the isolated zone.
[0027]
- The vacuum is maintained by the remaining zones unless their own valves are in the closed state.
[0028]
- After the workpiece has reached the set-down position, the vacuum circuit is vented by the vent valve.
[0029]
- The workpiece is held until the vent valve has opened the circuit.
[0030]An operation whose condition is not met does not run. A condition that is stated with UNLESS holds except while its event is true, and one stated with UNTIL ends the operation at the moment its event becomes true. With the workpiece released, the tool returns to the pick position and the cycle repeats.
6. Example Embodiments
[0031]In one embodiment the gripping face carries 1 bellows cups on a common mounting, fed as shown in FIG. 1, and the tool is presented to the workpiece square to the face. In a second embodiment the same face is arranged in two rows so that a long workpiece is supported at both ends, with the connections of FIG. 1 unchanged. In a third embodiment the face is built at half the pitch and the number of bellows cups is doubled for the same envelope, which suits a workpiece that is lighter but less rigid.
[0032]In a further embodiment the zones are sized so that the smallest workpiece in the range covers one whole zone, so that no partly covered zone has to be held under vacuum at any point in the cycle.
7. Alternative Configurations
[0033]The gripping face may instead use a folded bellows cup, which takes up height differences at the cost of lateral stiffness. The gripping face may instead use an array of discrete cups, which concentrates the holding force at the lips and needs a sealing surface. A gripping face of this kind may also be replaced by fingers closing on the workpiece, which removes the air circuit entirely and requires access to two opposed surfaces of the workpiece. The ejector may be replaced by a pump at the tool, which stops the continuous air draw and adds mass to the moving assembly, or by a connection to a plant vacuum line, which removes the generator from the tool and couples the tool to the rest of the site. The isolation valve may be provided once for the whole circuit rather than per zone, which is simpler and gives up the ability to hold vacuum on a covered zone while another is open. The vent may be supplemented by a blow-off pulse, which clears the face rather than waiting for it to refill.
8. Parameter Variations
[0034]Each parameter below is stated with what it changes in the arrangement. The folds of the bellows cup is 2 in the arrangement described; varying it changes the travel taken up at the face and the lateral stiffness under load. The material of the bellows cup is plastic in the arrangement described; varying it changes the friction at the lip and the resistance of the fold to fatigue. The stages of the ejector is 3 in the arrangement described; varying it changes the flow drawn at low vacuum and the air consumed to hold a sealed face. The control of the isolation valve is per zone in the arrangement described; varying it changes whether one zone can be cut on its own or only the whole circuit. The zones of the zone branch is 2 in the arrangement described; varying it changes how much of the face can be isolated at once and how small a workpiece the tool can still hold. The placement of the contact detector is on the frame in the arrangement described; varying it changes whether contact is reported for the face as a whole or for one part of it. The timing of the vent valve is after set-down in the arrangement described; varying it changes whether the workpiece is released before or after it is supported.
9. Additional Implementations
[0035]A pressure sensor may be tapped into the circuit so that the state of the grip is observable, and the motion that follows the grip may be made conditional on the level it reports. The whole assembly may be carried on a tool-change interface so that it can be exchanged between jobs without dismantling the tool. A separating element may be added so that a workpiece which follows the face upwards after release is pushed off positively. The arrangement may be duplicated on one mounting so that two workpieces are handled in one cycle, with the distribution fed from a common inlet and each face controlled on its own.
10. Provenance and method
[0036]This document is an original combination composed from a typed library of mechanism blocks. Each block was derived from the published patent literature and carries typed connection points, the parameters its source states, and its own construction and operating description. The combination described here is proposed rather than taken from any one source, and it is not asserted to have been constructed. The published documents behind the blocks used in this arrangement are EP-4489564-B1, US-10163334-B1, US-10549431-B2, US-2022339798-A1, WO-2008134339-A4, WO-2026020244-A1. Their text is not reproduced here; the description above is generated from the structure of the combination.
11. Figures