OT-2026-000003089
Robot system
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003089
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- DOI KOJI
- Assignee
- KAWASAKI HEAVY IND LTD
- Original source
- US-2001033144-A1, the United States Patent and Trademark Office, 25 October 2001
- Document SHA-256
- f682d6c1665bd9d072ab40f5f447d2af35c1ab4d1ada7aa55bb8ba083cfa1c46
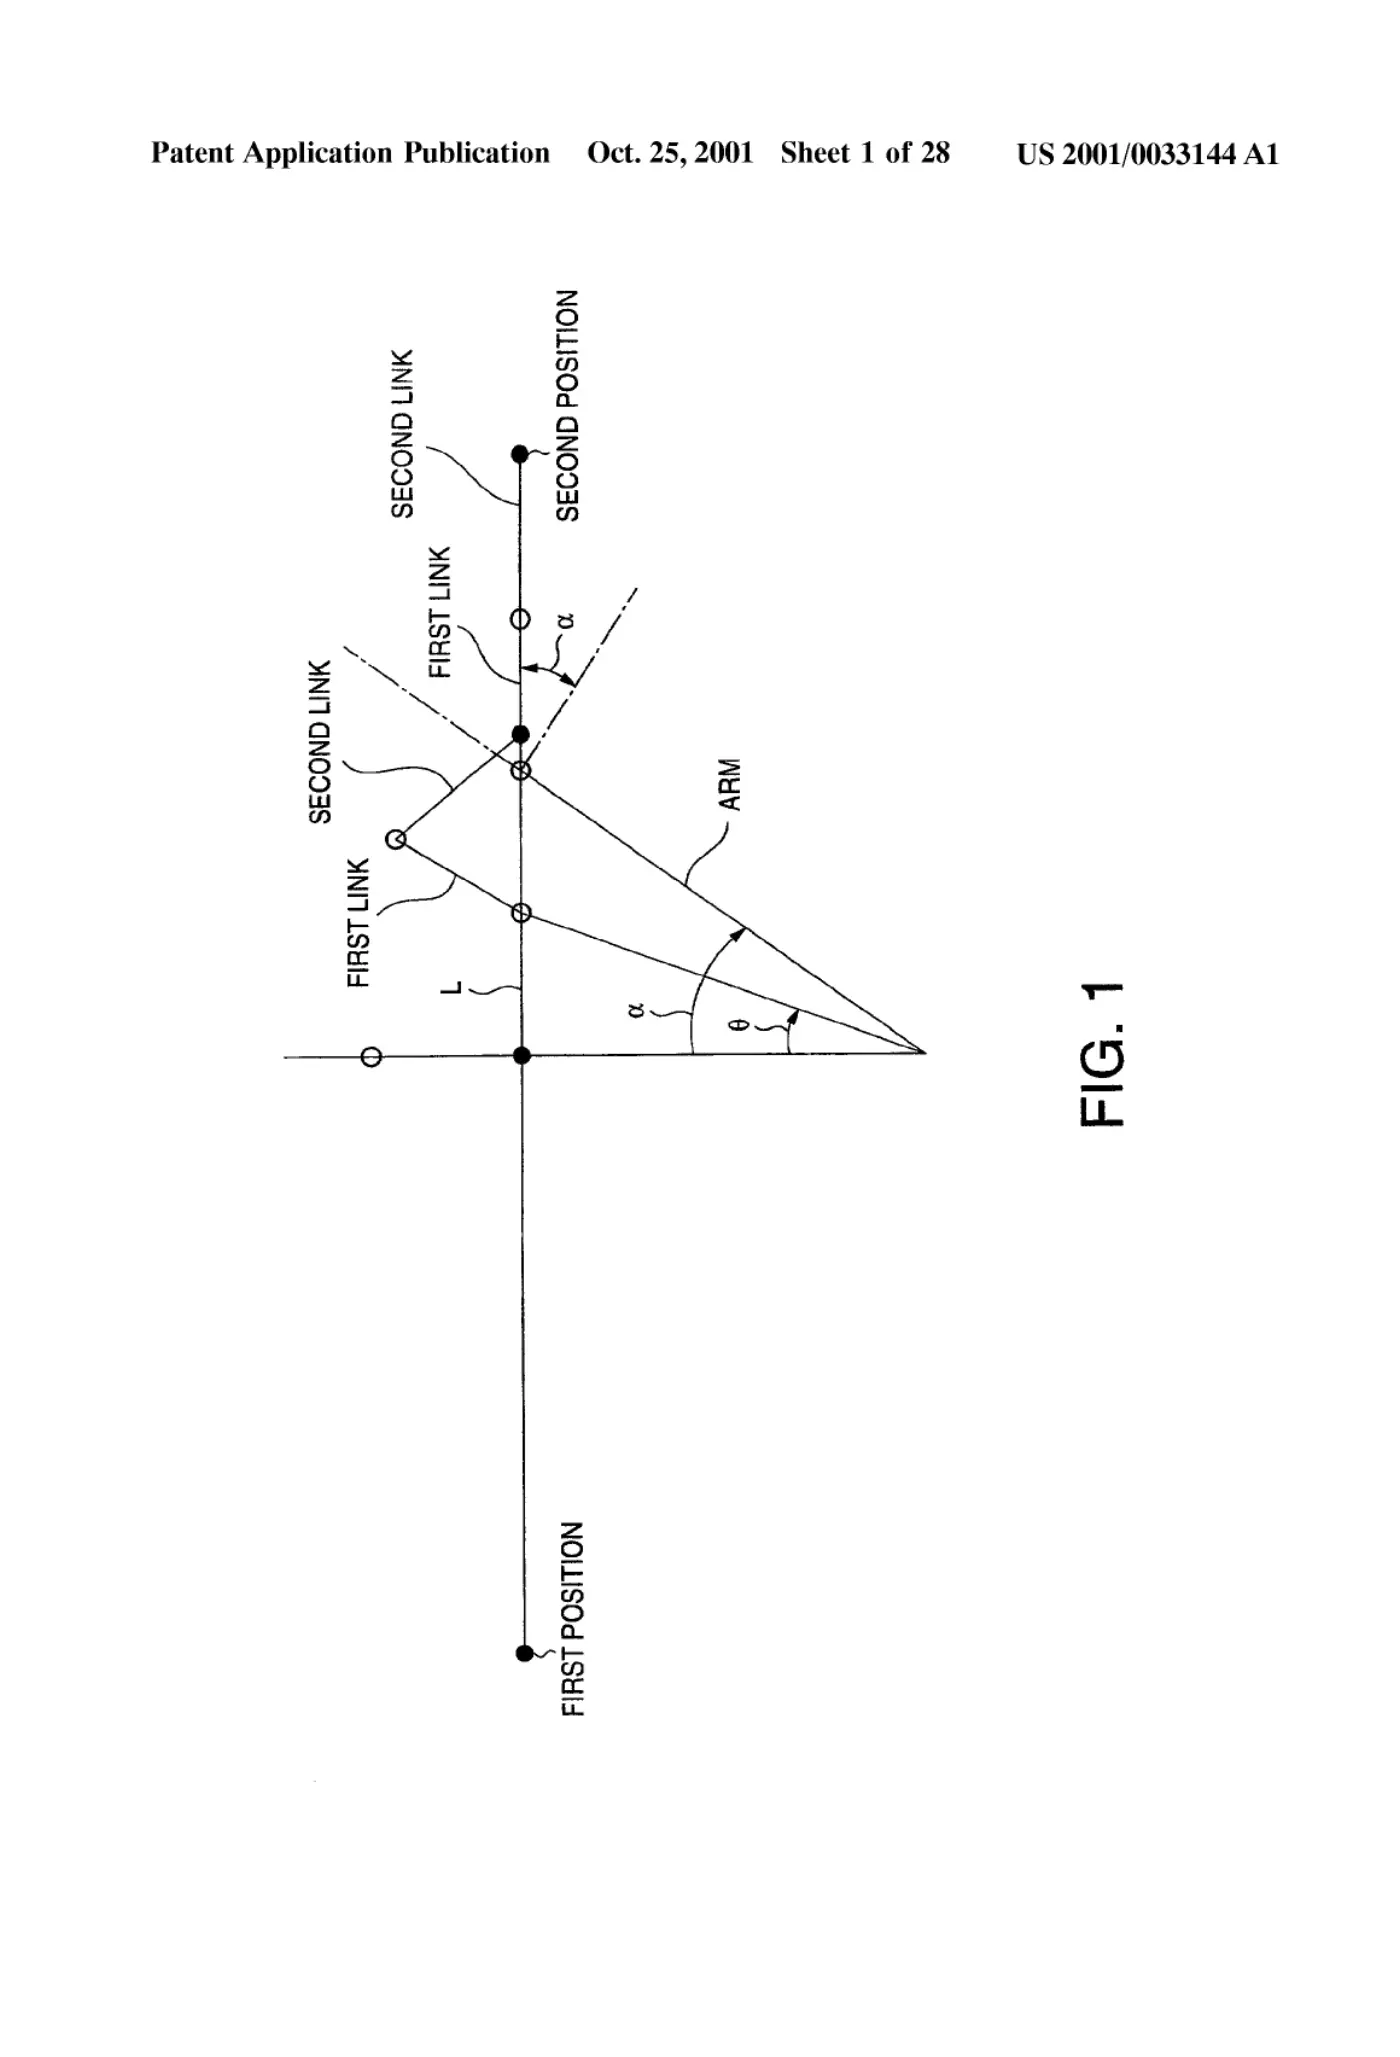
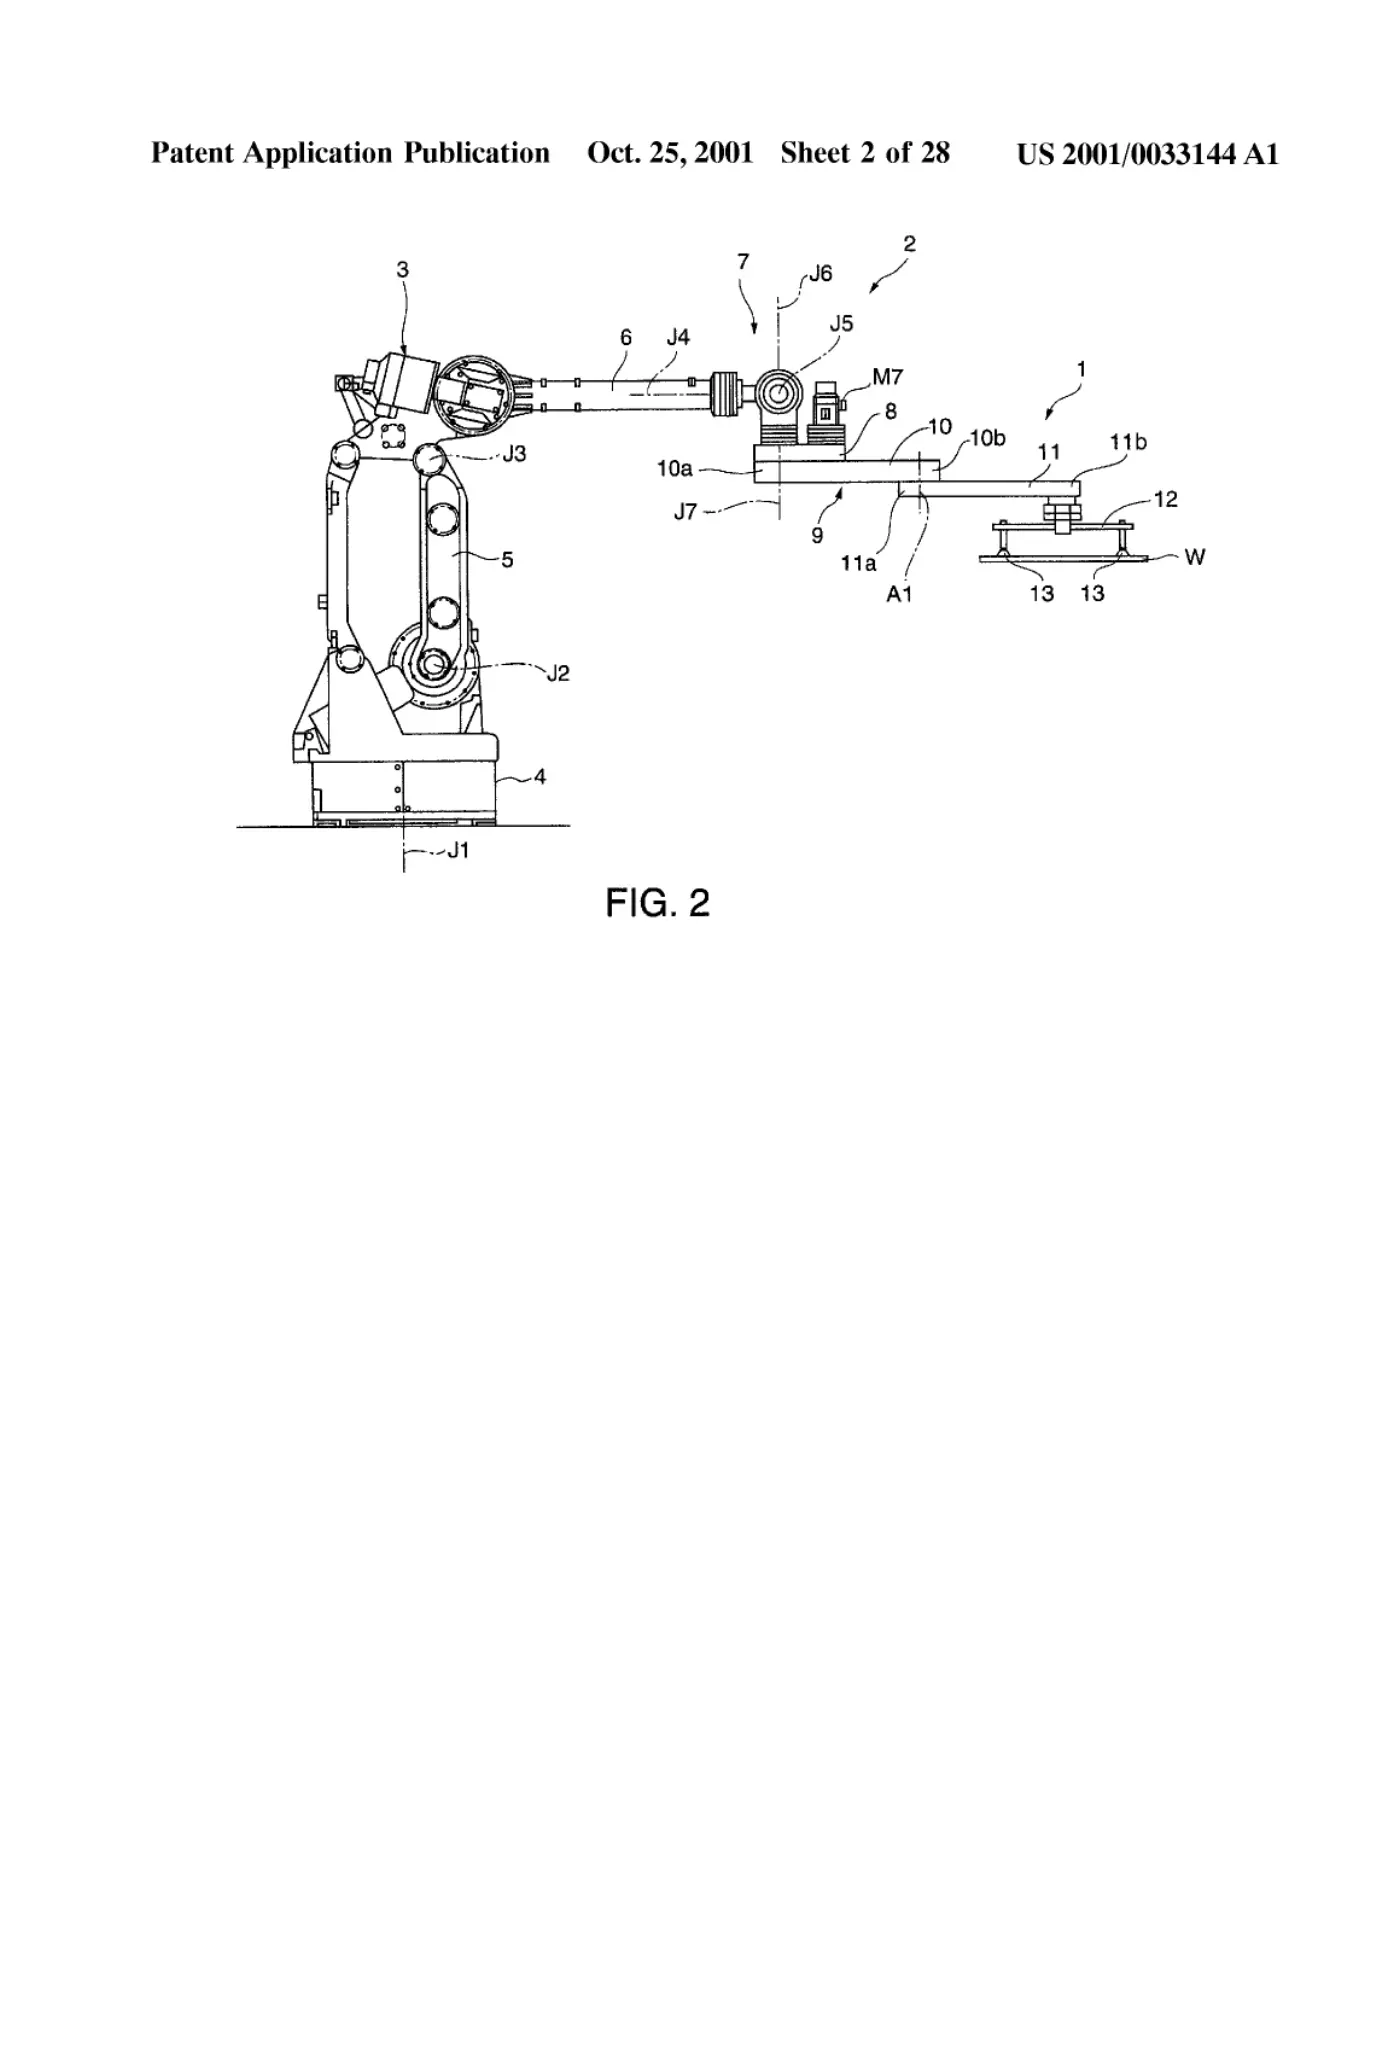
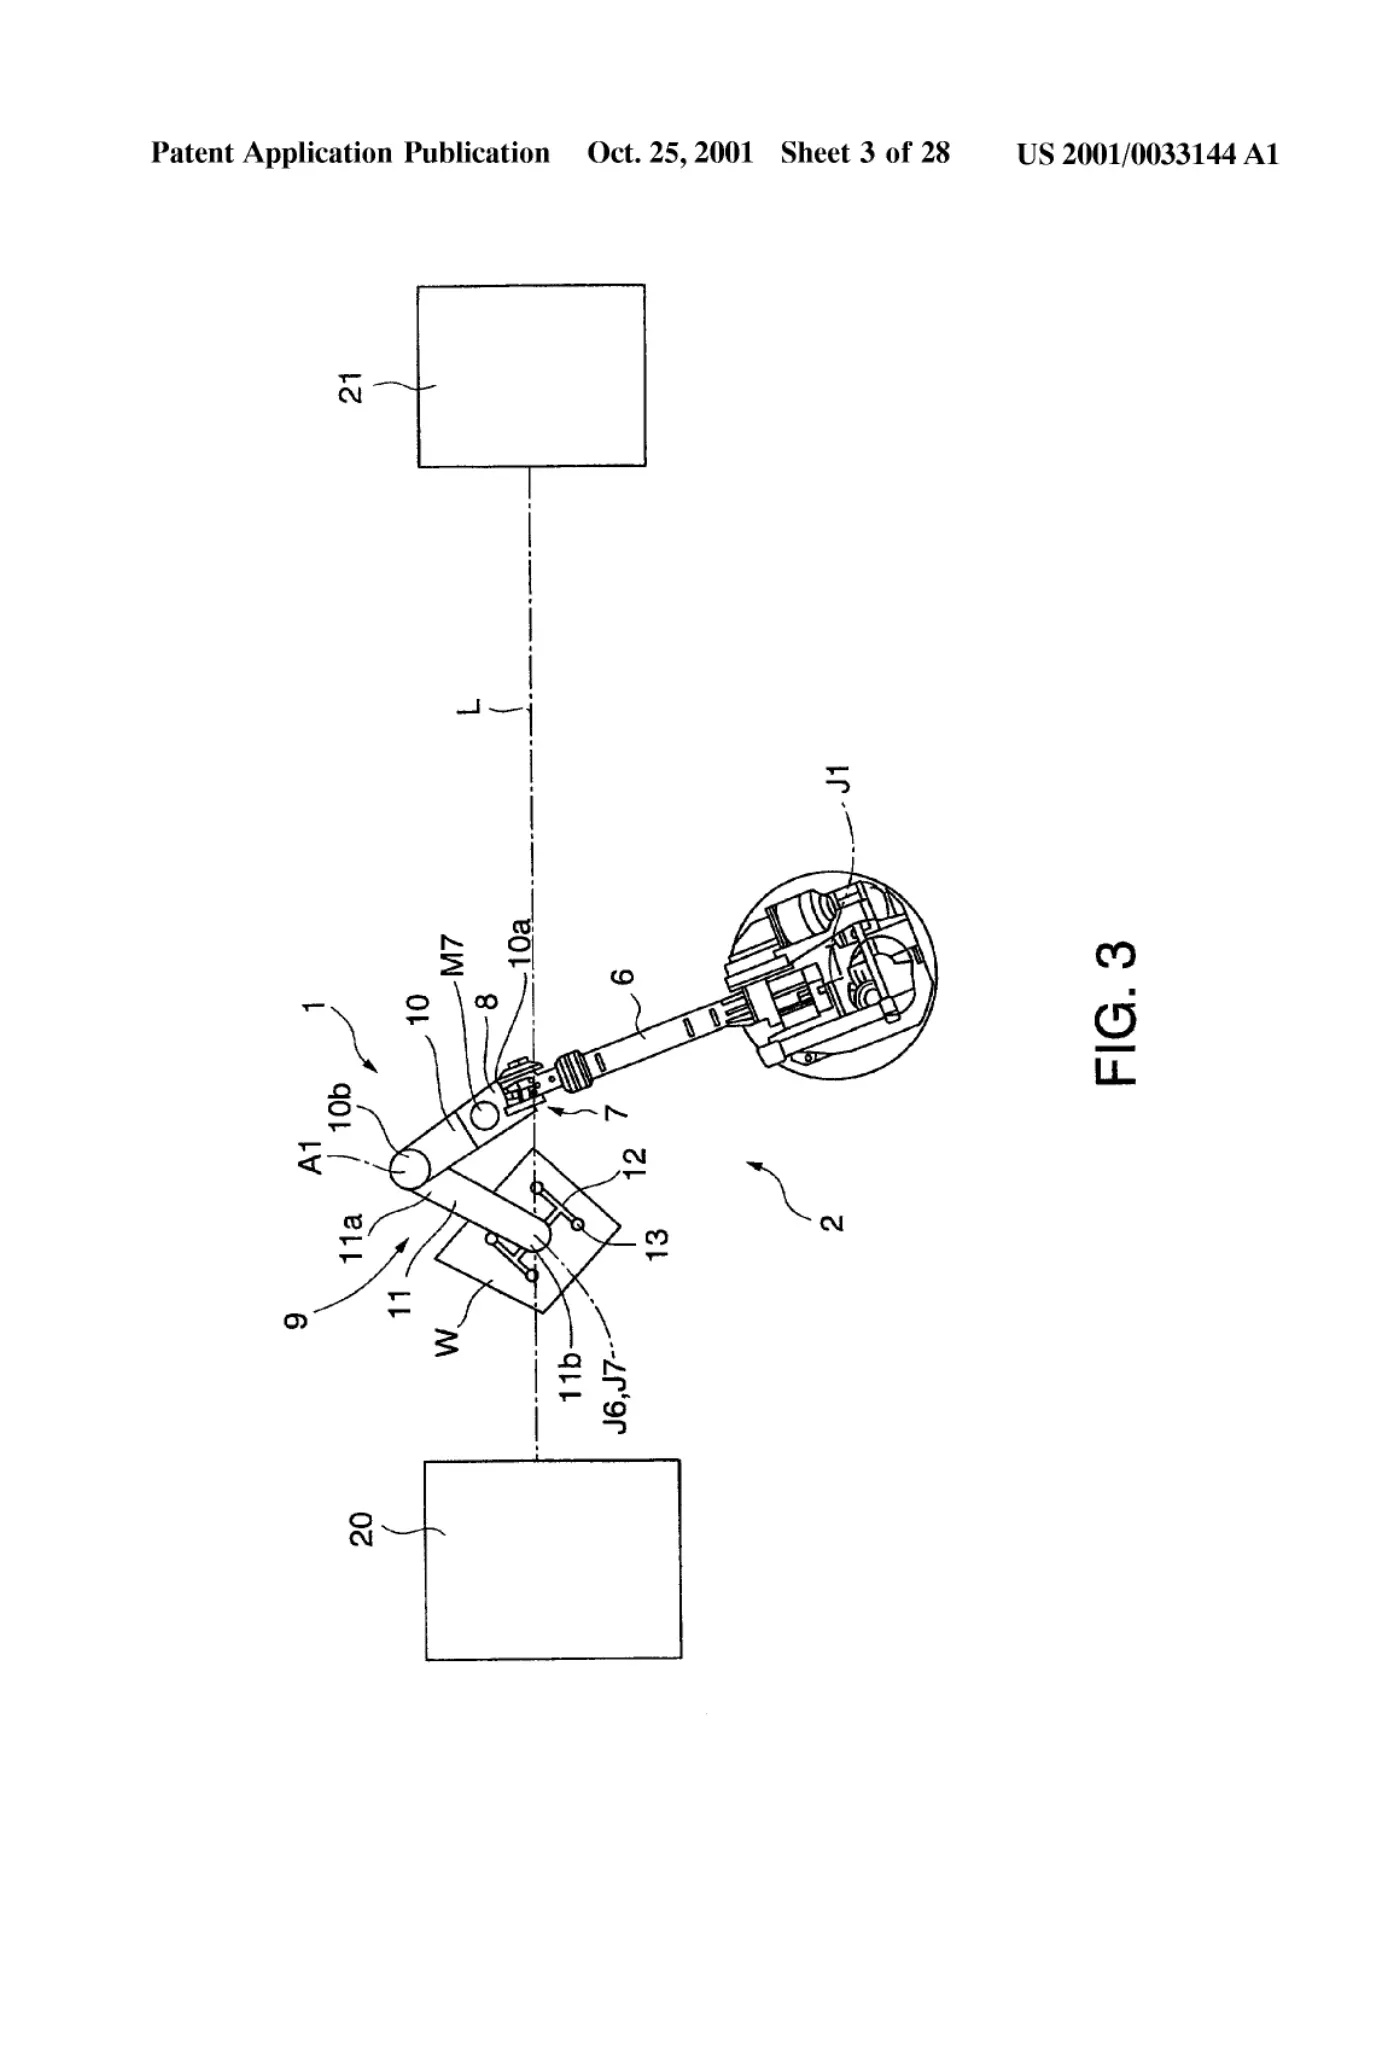
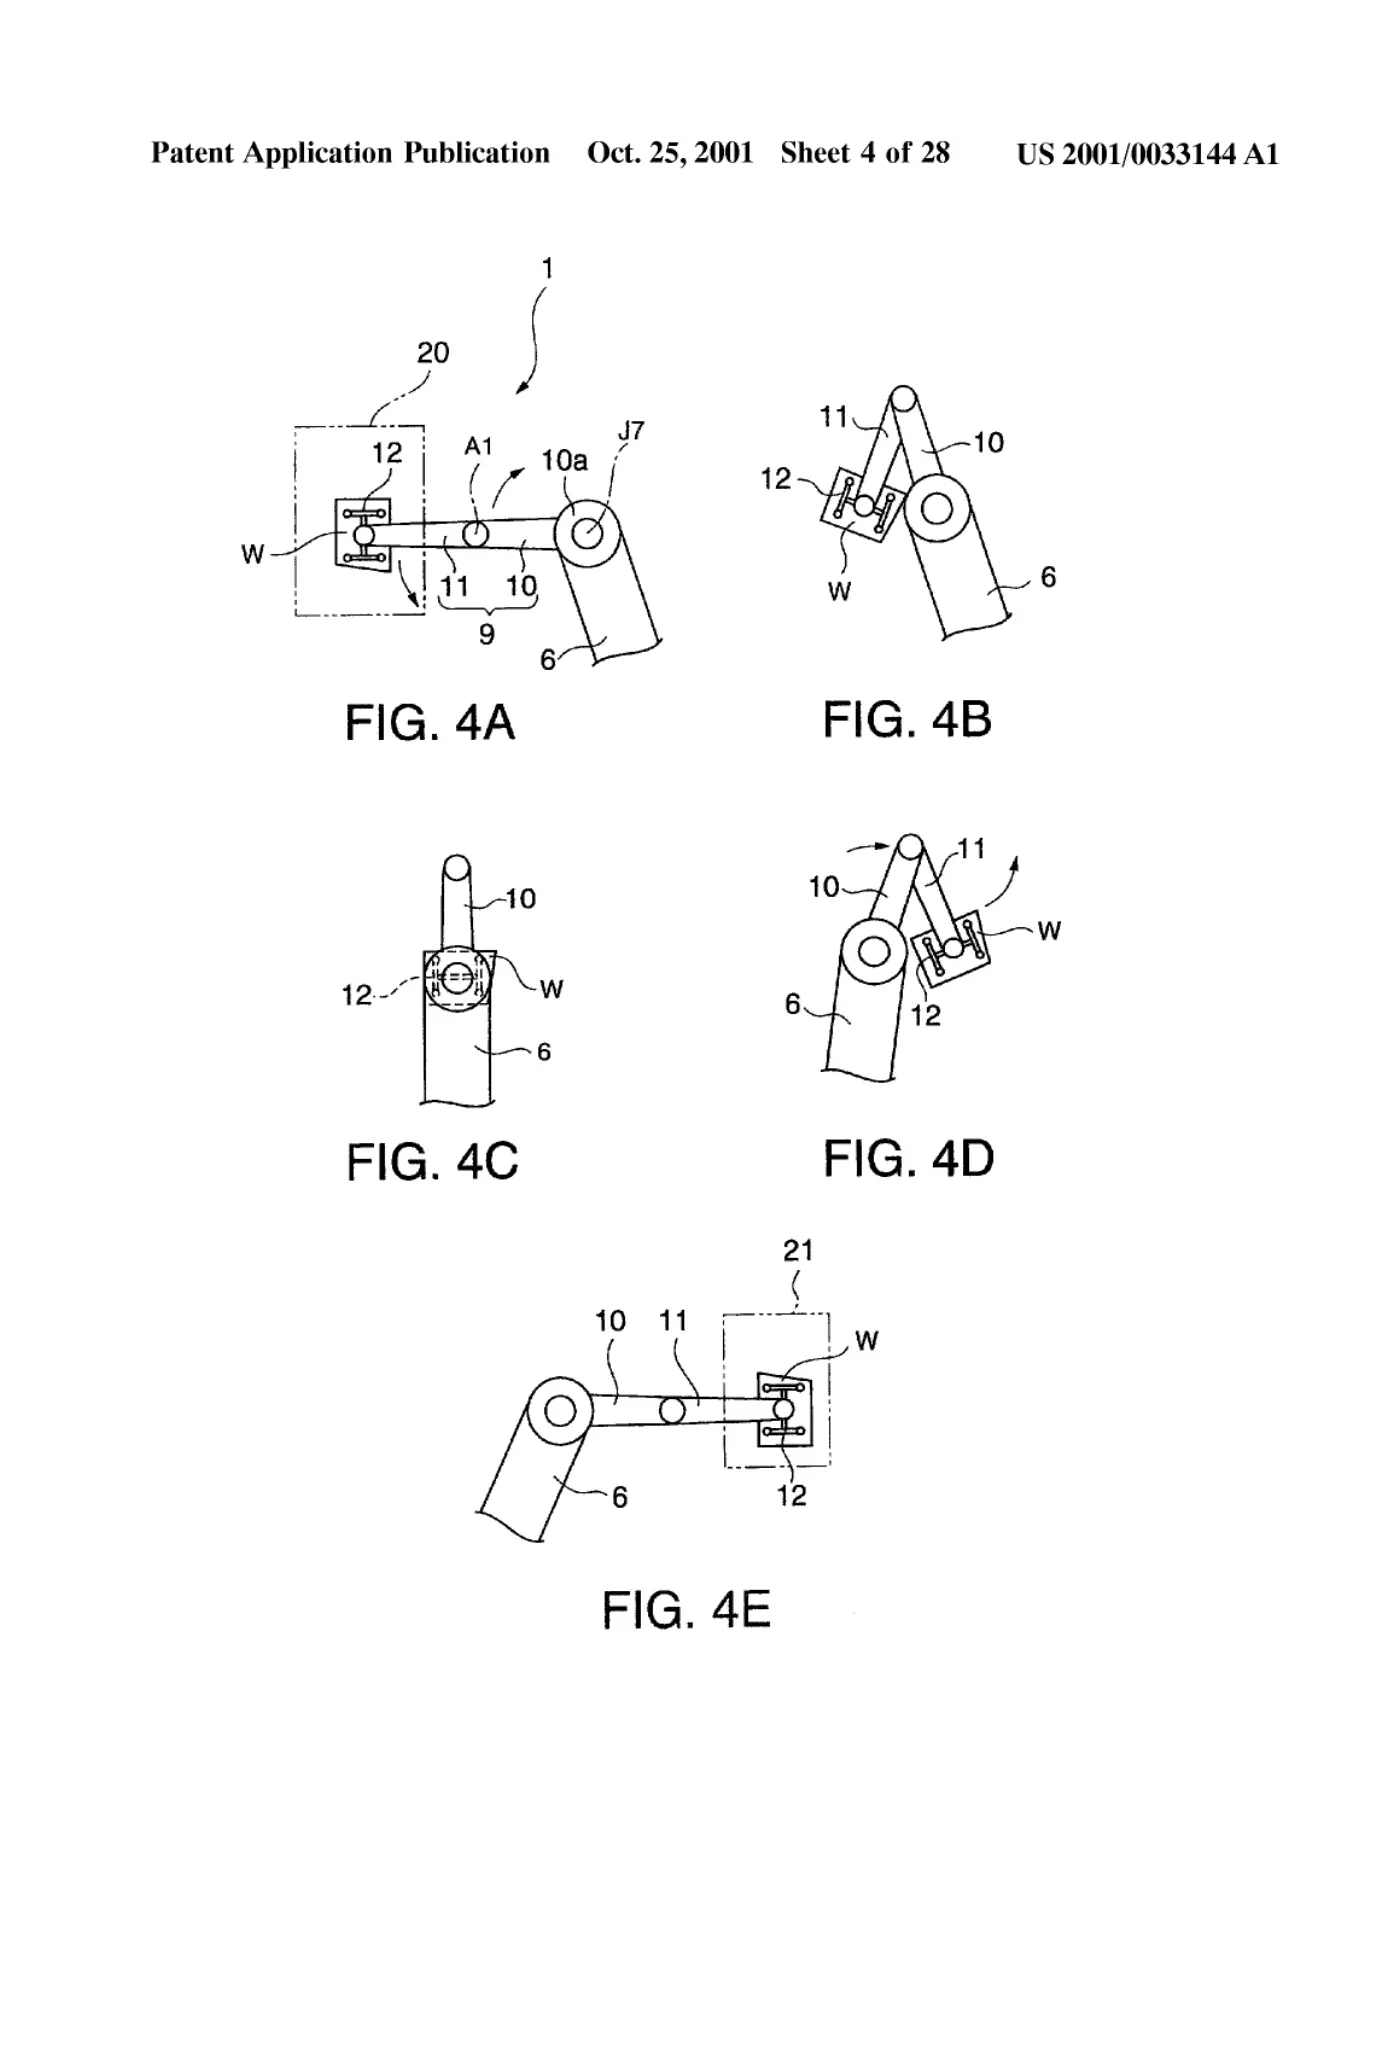
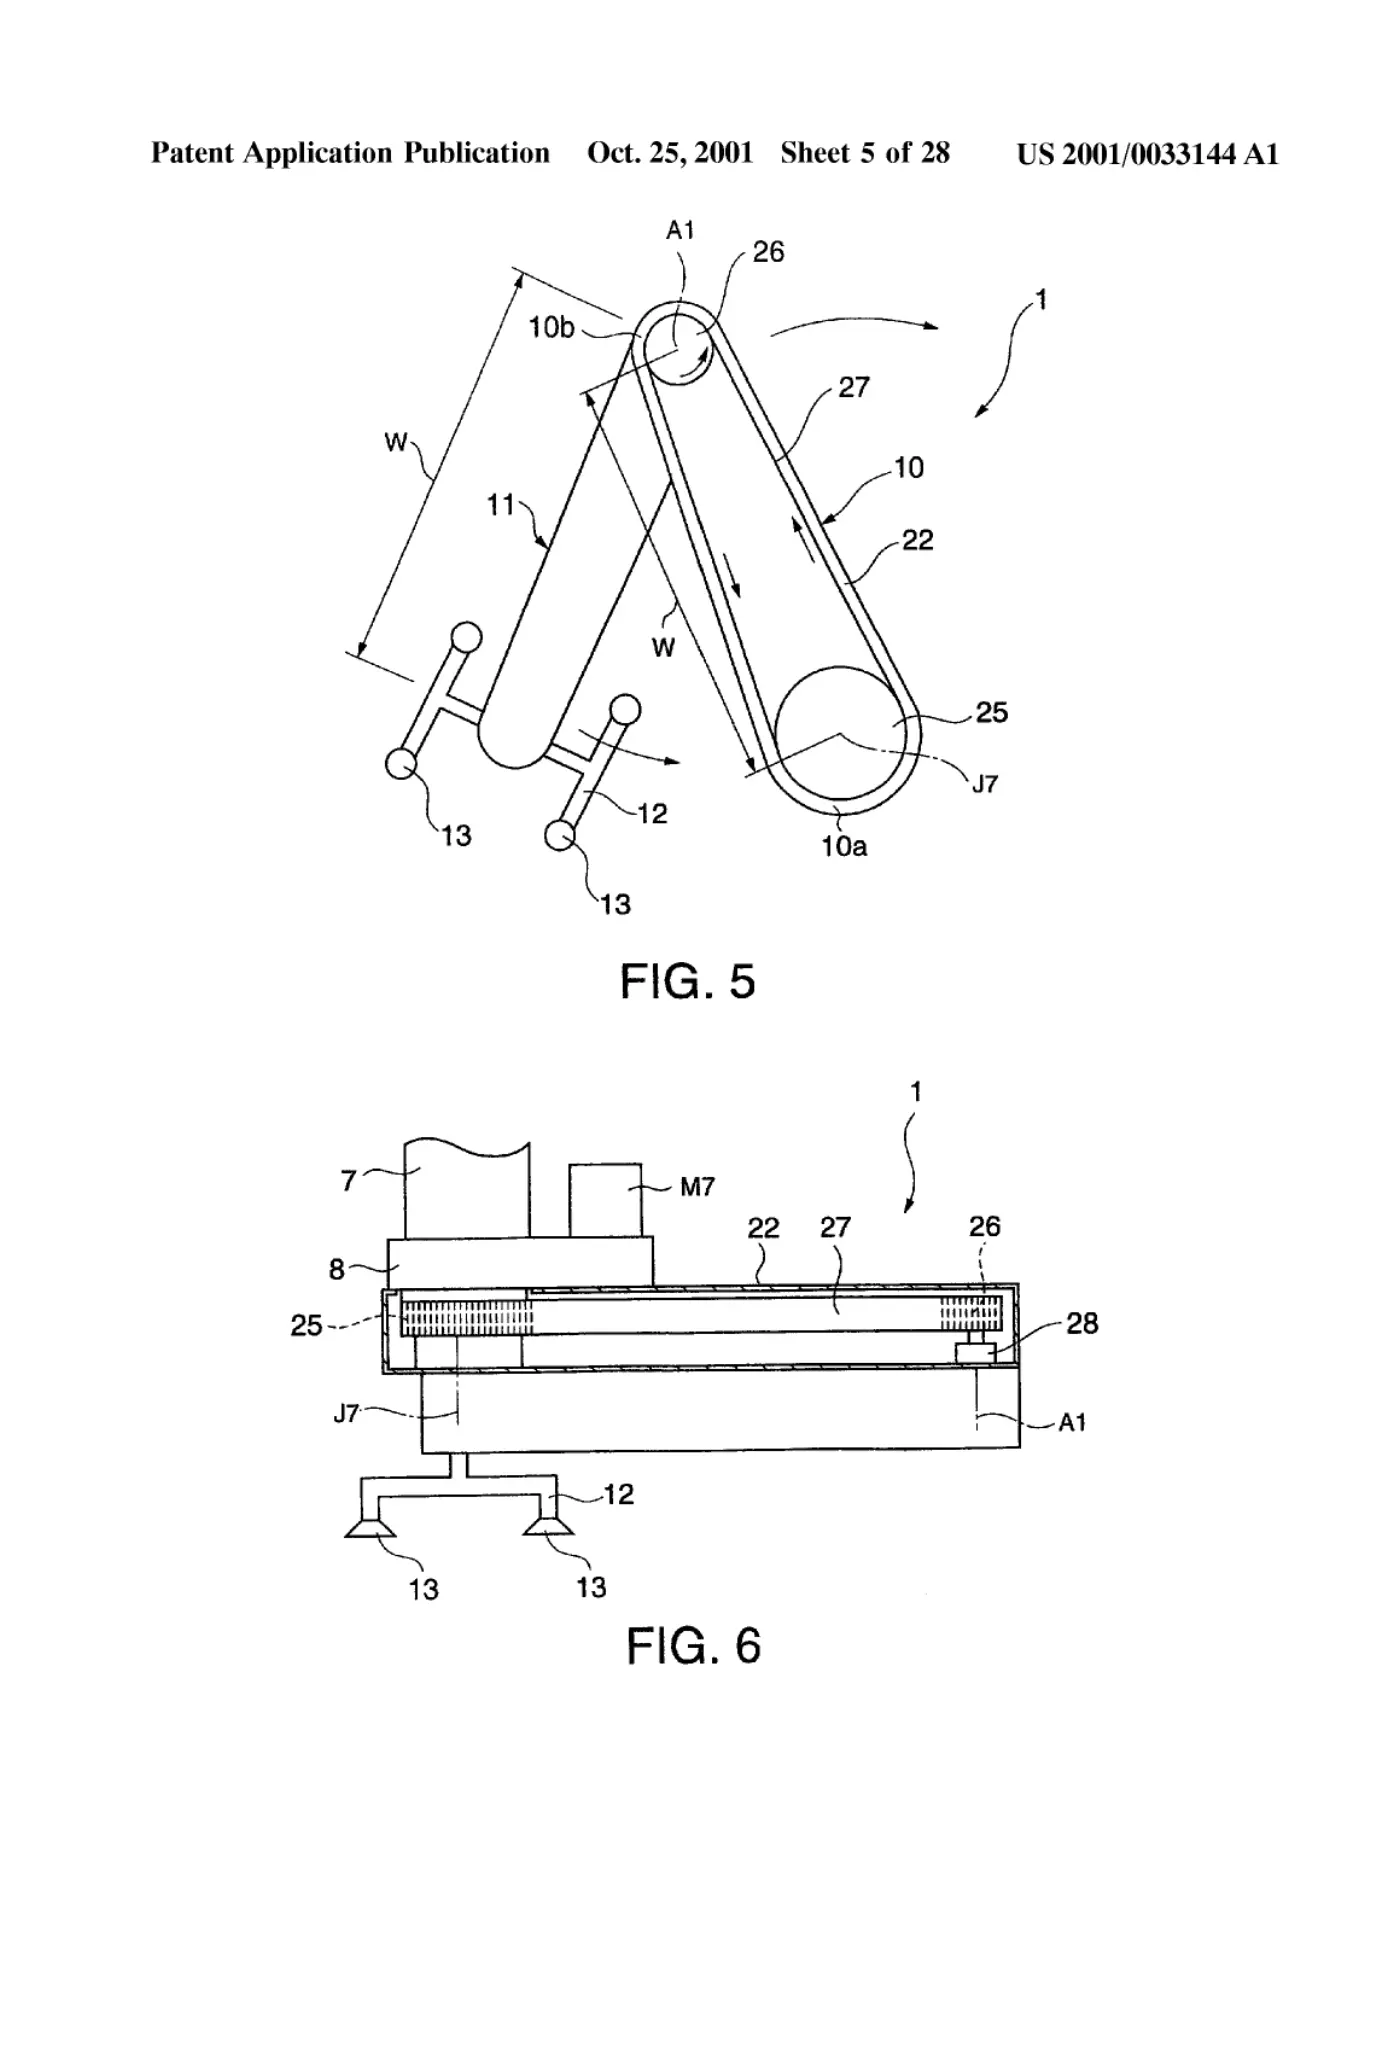
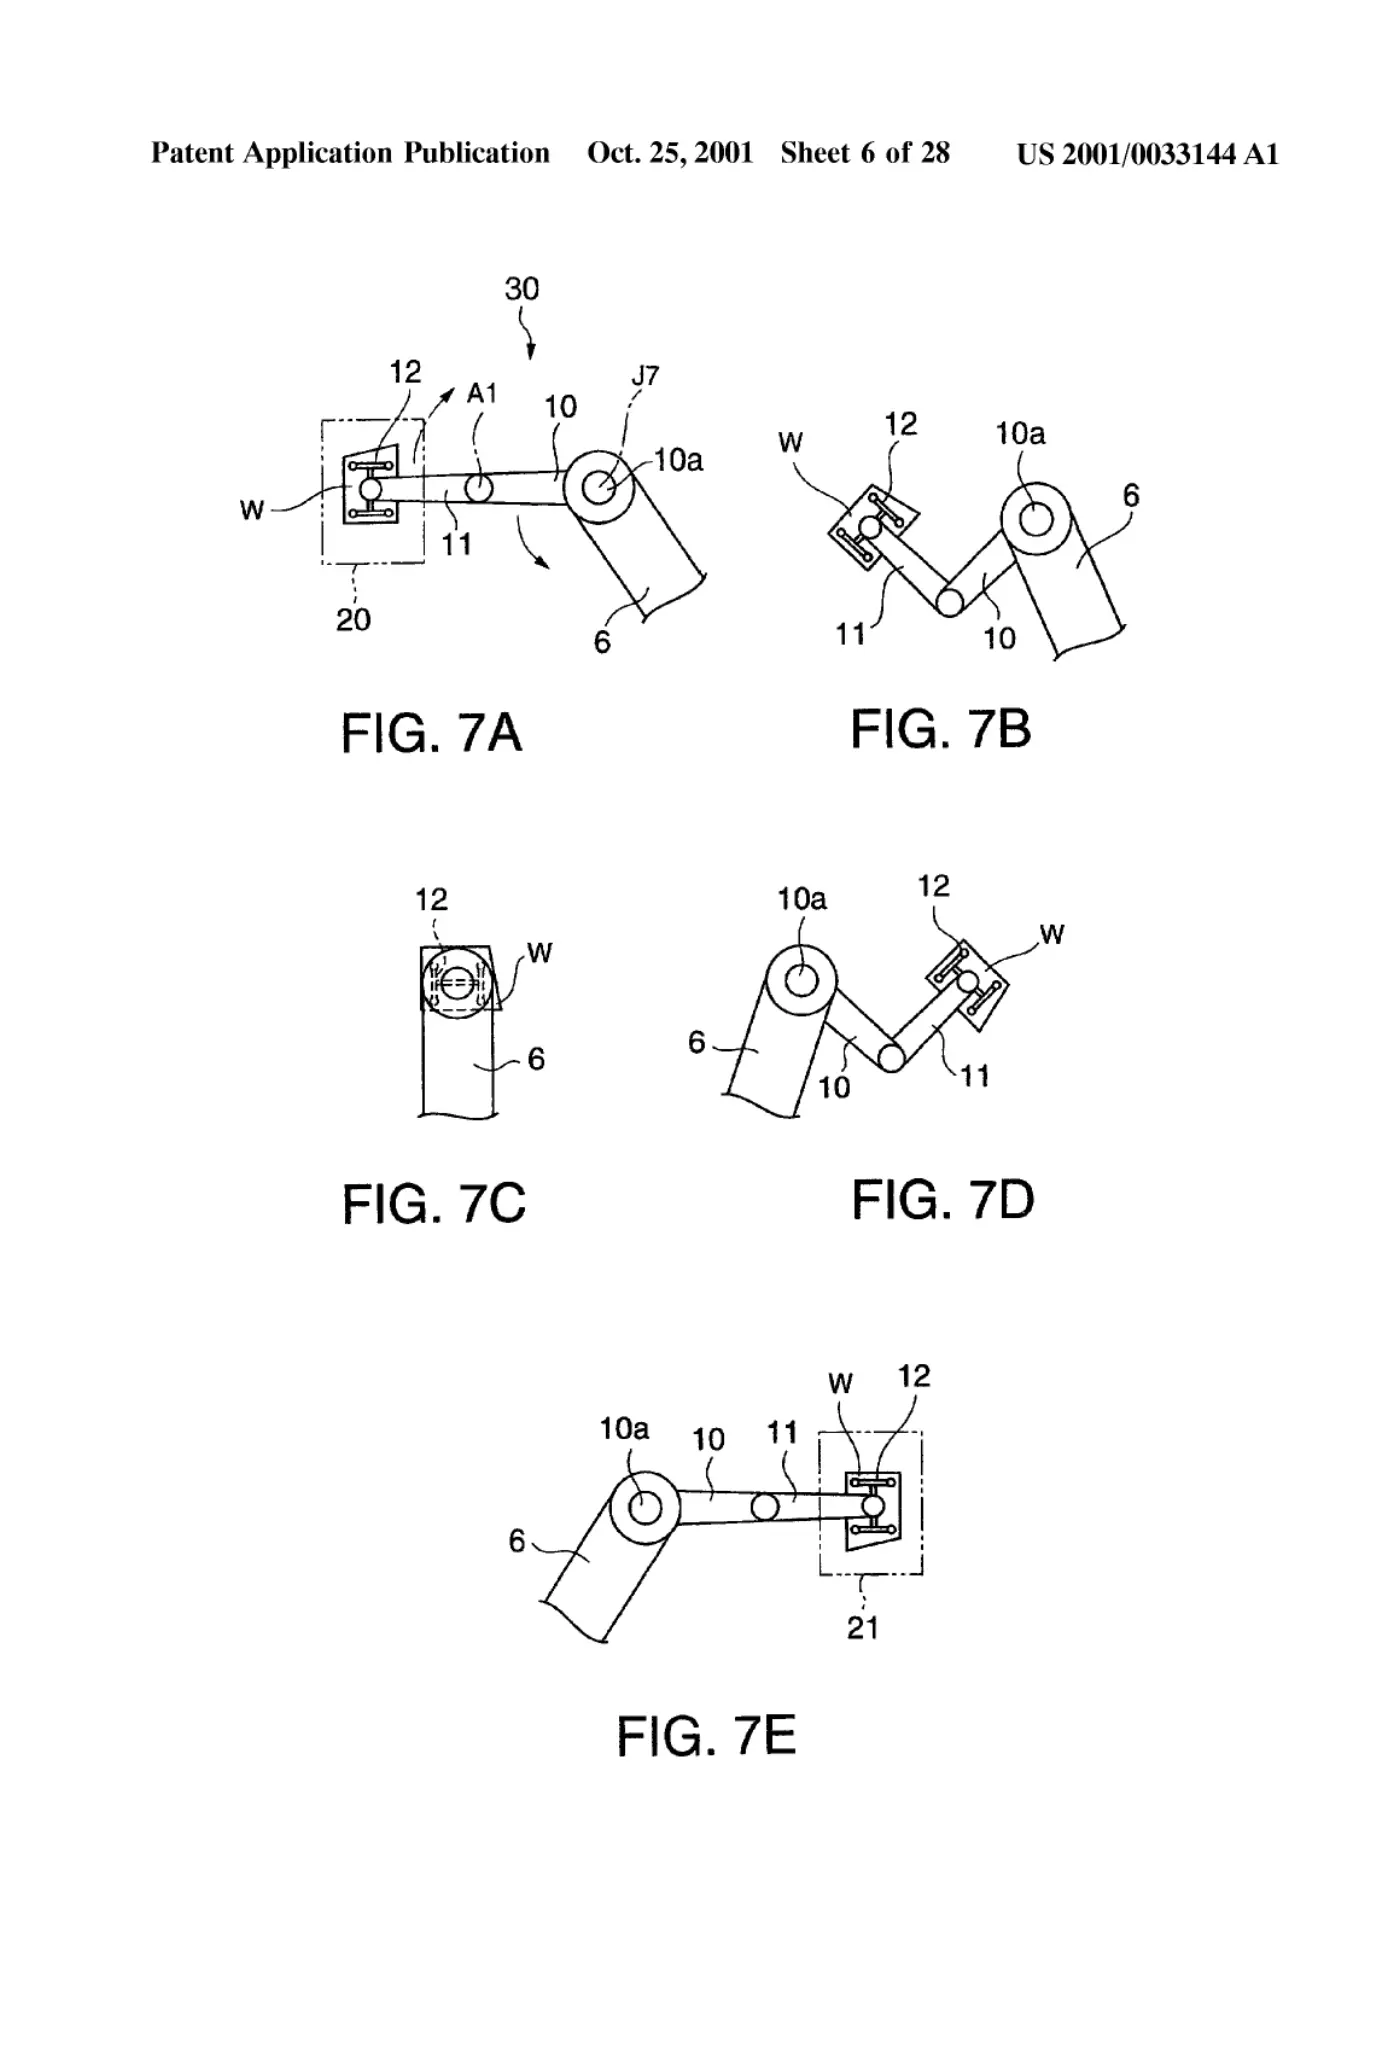
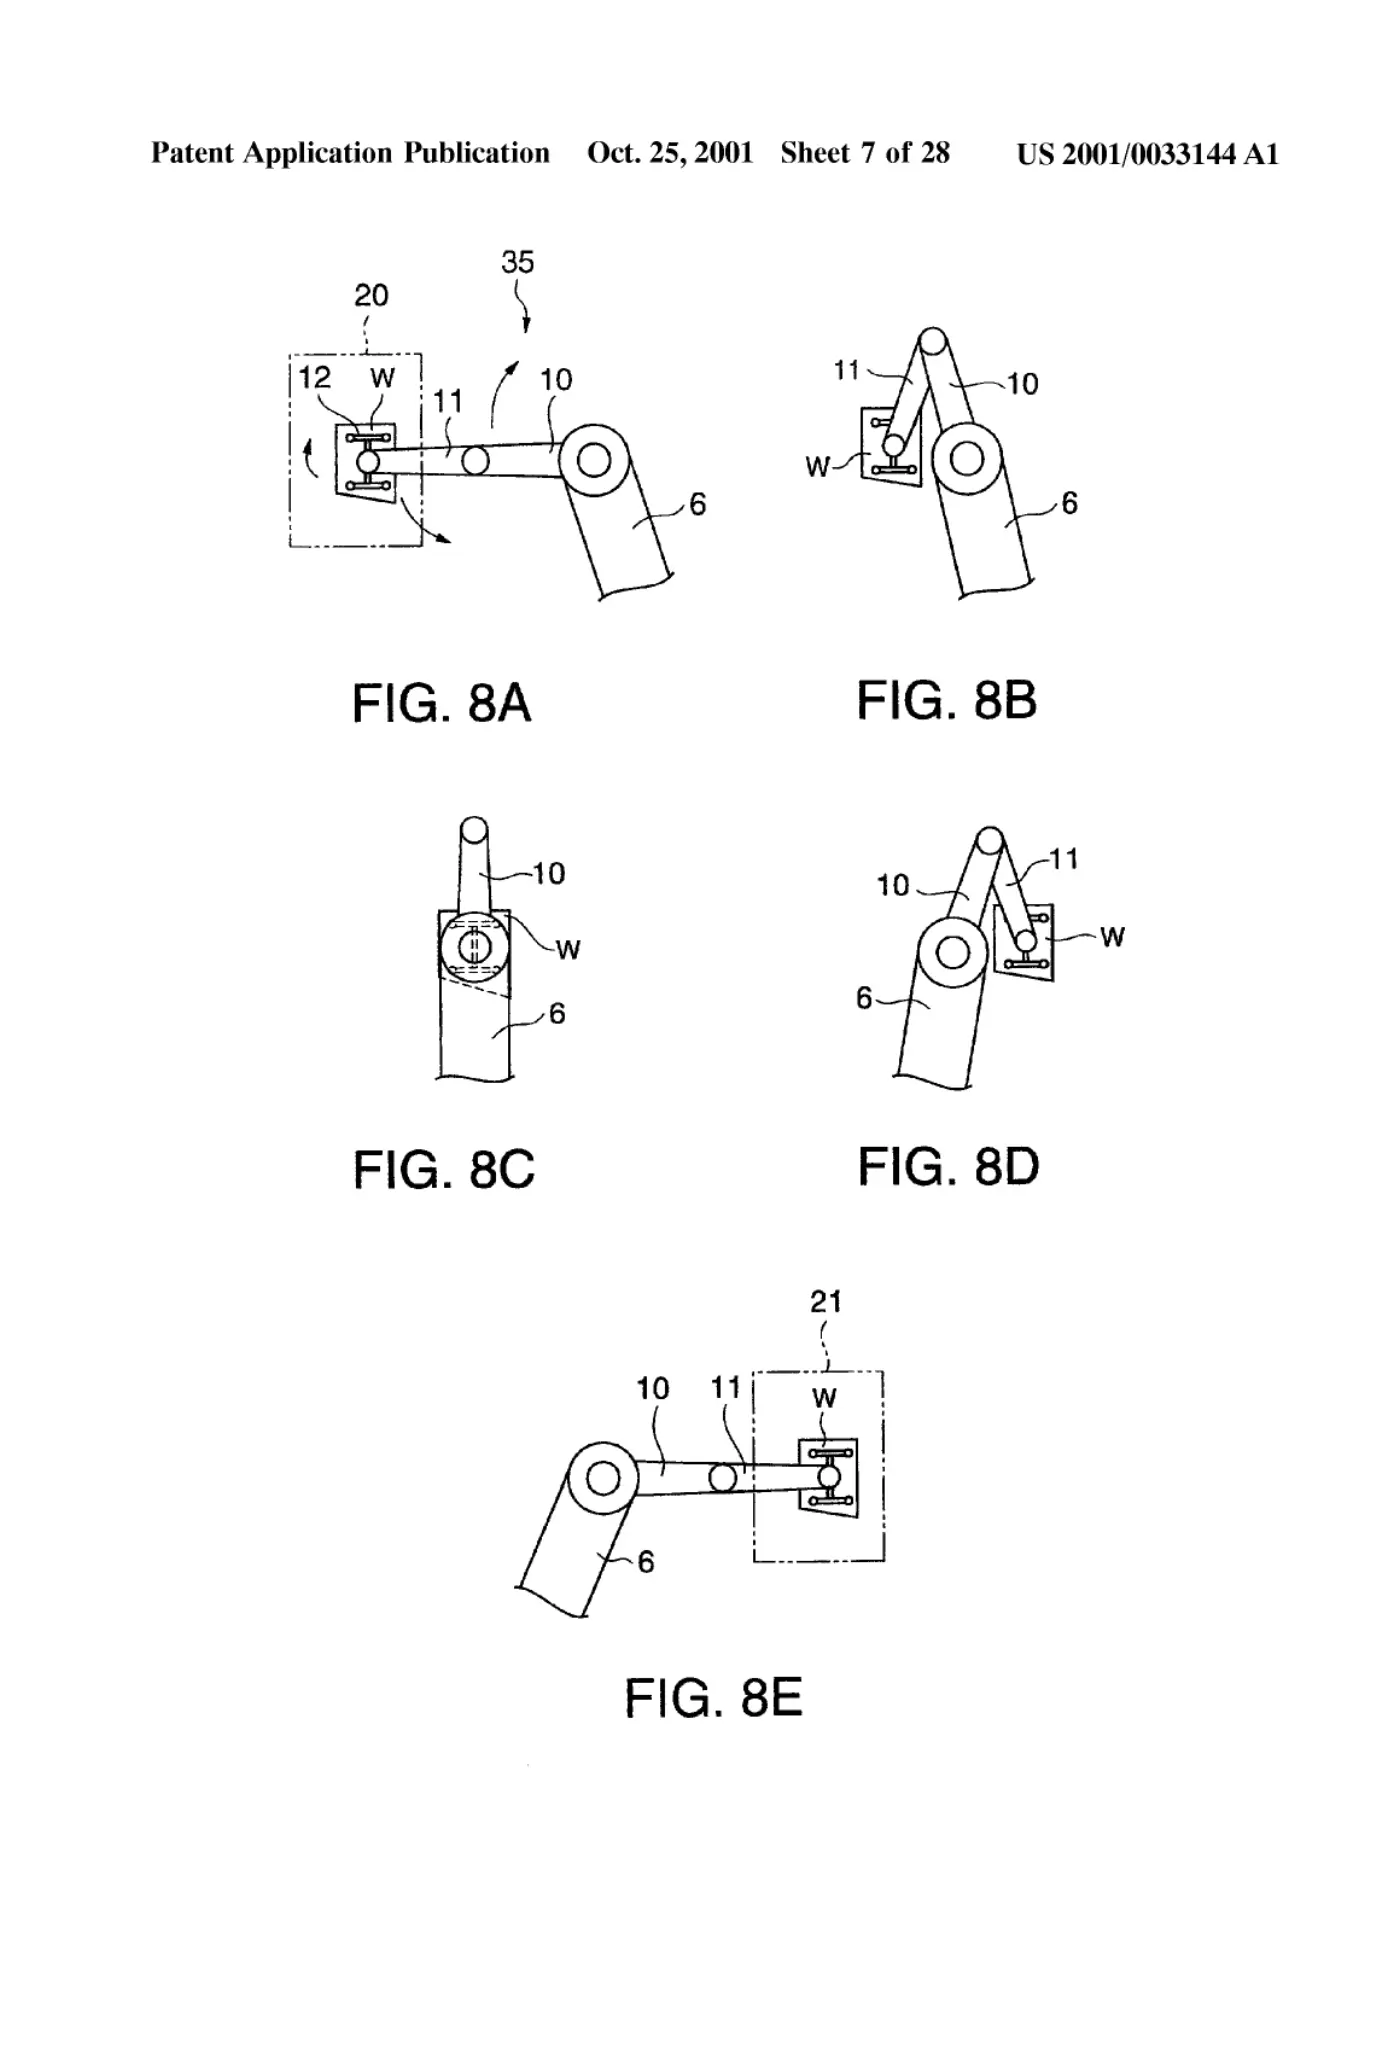
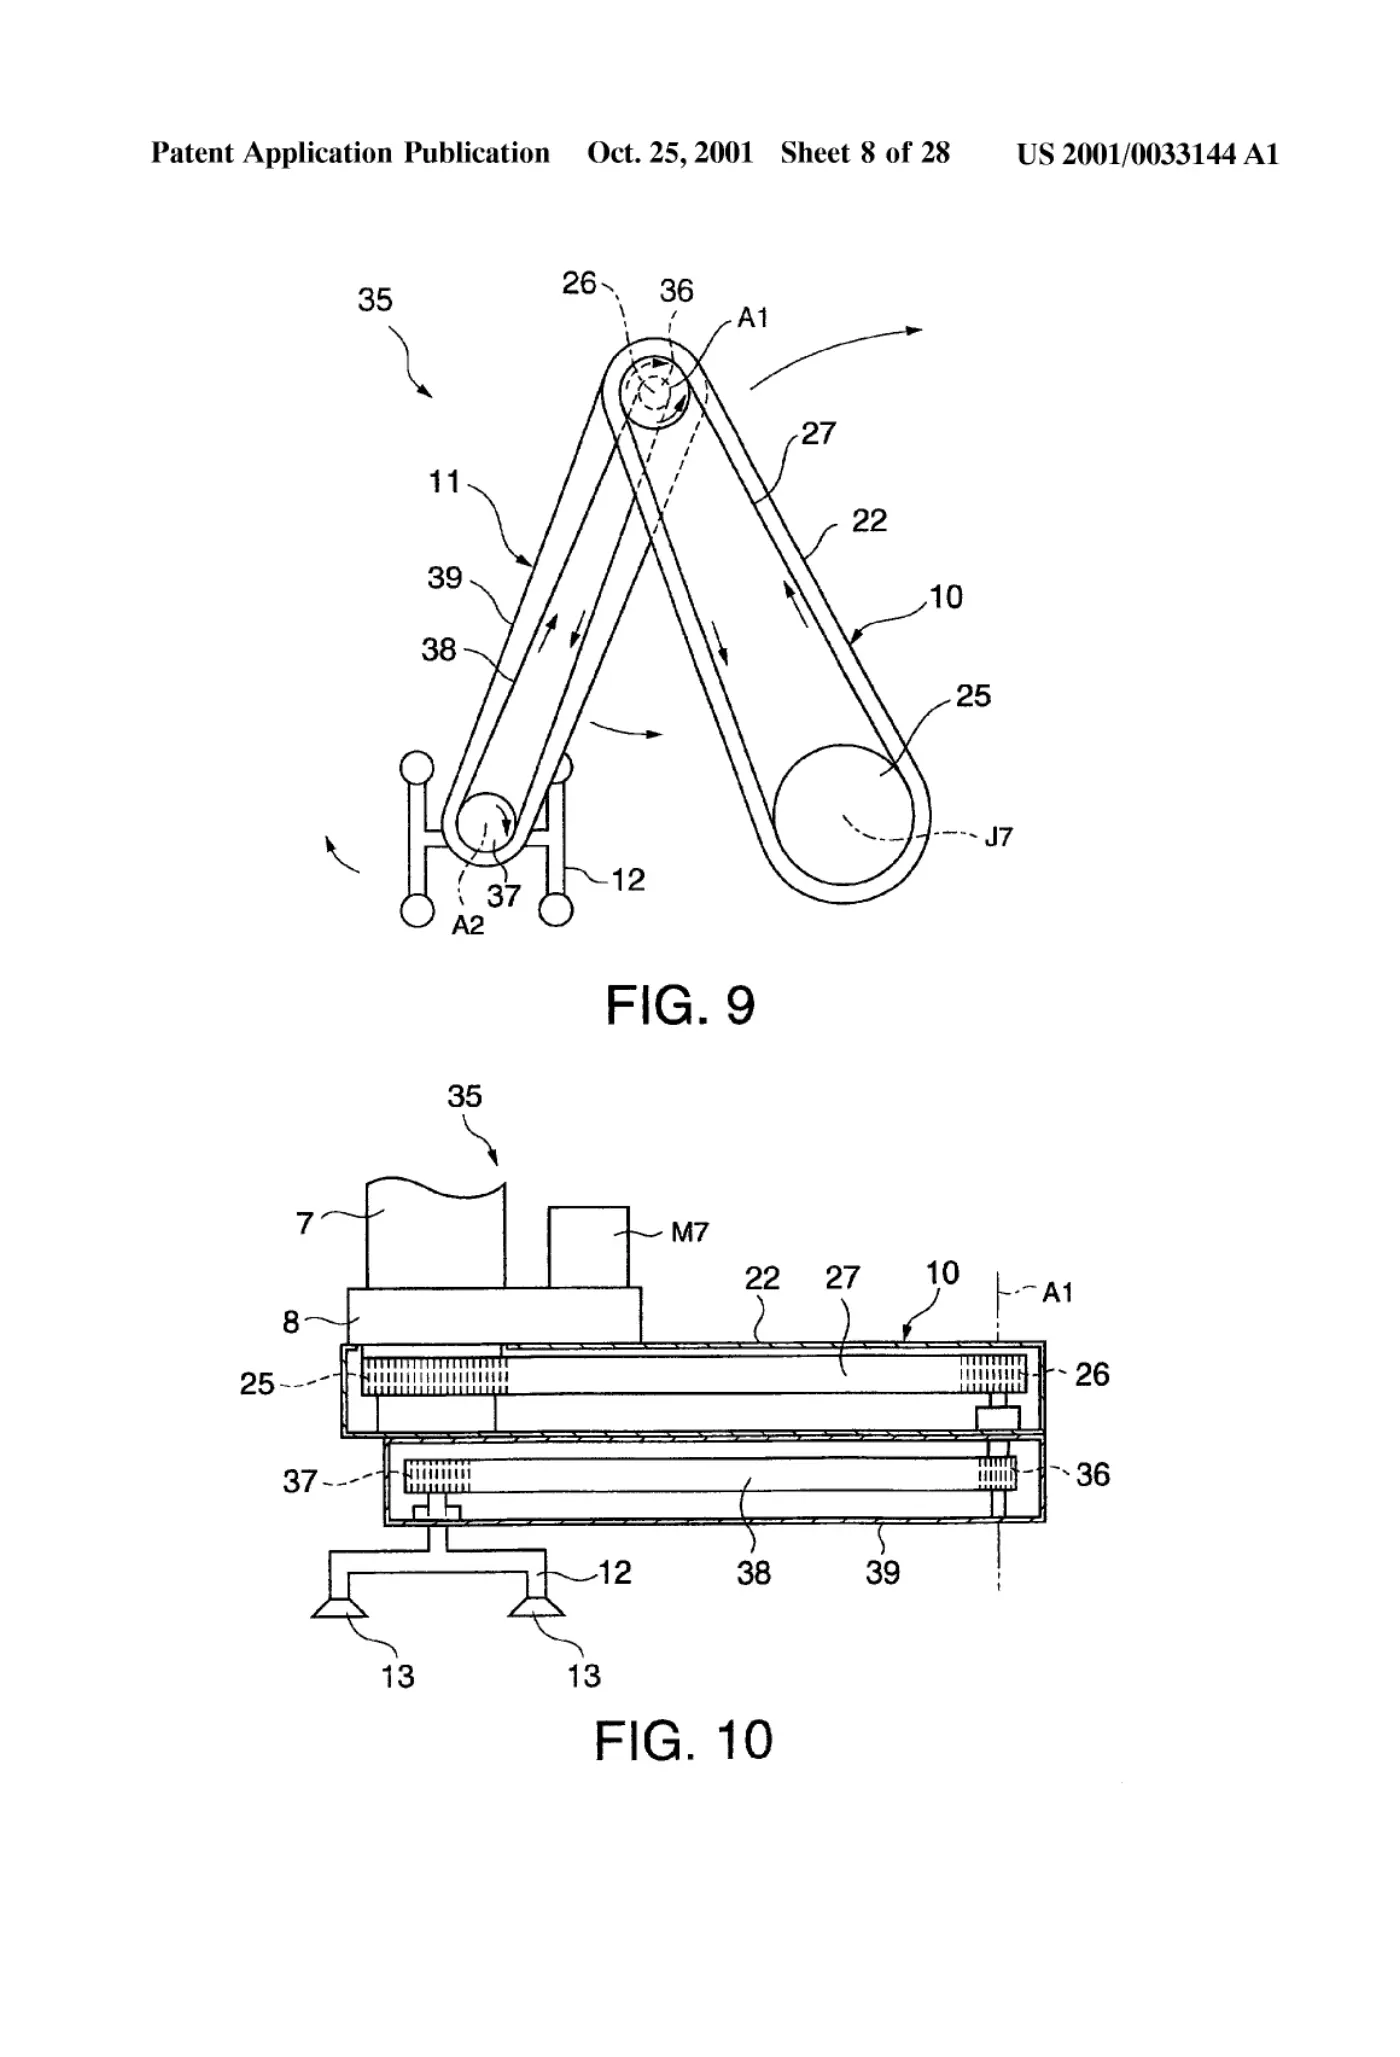
The robot system including a 6-axis robot has a swingable arm for transferring a workpiece between first and second positions, a wrist on a distal end of the arm, that is driven to rotate around a predetermined axis, and a transfer device at the wrist. The transfer device has a link mechanism having first and second links and holding means attached to a distal end of the second link. A proximal end of the first link is attached to the wrist so as to rotate around the predetermined axis. A distal end of the first link and a proximal end of the second link are rotatably connected to each other. In accordance with a swinging motion of the arm, the first link rotates in a first rotational direction with respect to the arm and the second link rotates in a second rotational direction opposite to the first rotational direction with respect to the first link, so as to transfer the workpiece along a straight line linking the first and second positions.
Abstract
The robot system including a 6-axis robot has a swingable arm for transferring a workpiece between first and second positions, a wrist on a distal end of the arm, that is driven to rotate around a predetermined axis, and a transfer device at the wrist. The transfer device has a link mechanism having first and second links and holding means attached to a distal end of the second link. A proximal end of the first link is attached to the wrist so as to rotate around the predetermined axis. A distal end of the first link and a proximal end of the second link are rotatably connected to each other. In accordance with a swinging motion of the arm, the first link rotates in a first rotational direction with respect to the arm and the second link rotates in a second rotational direction opposite to the first rotational direction with respect to the first link, so as to transfer the workpiece along a straight line linking the first and second positions.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
[0005]Sheet 5.
[0006]Sheet 6.
[0007]Sheet 7.
[0008]Sheet 8.
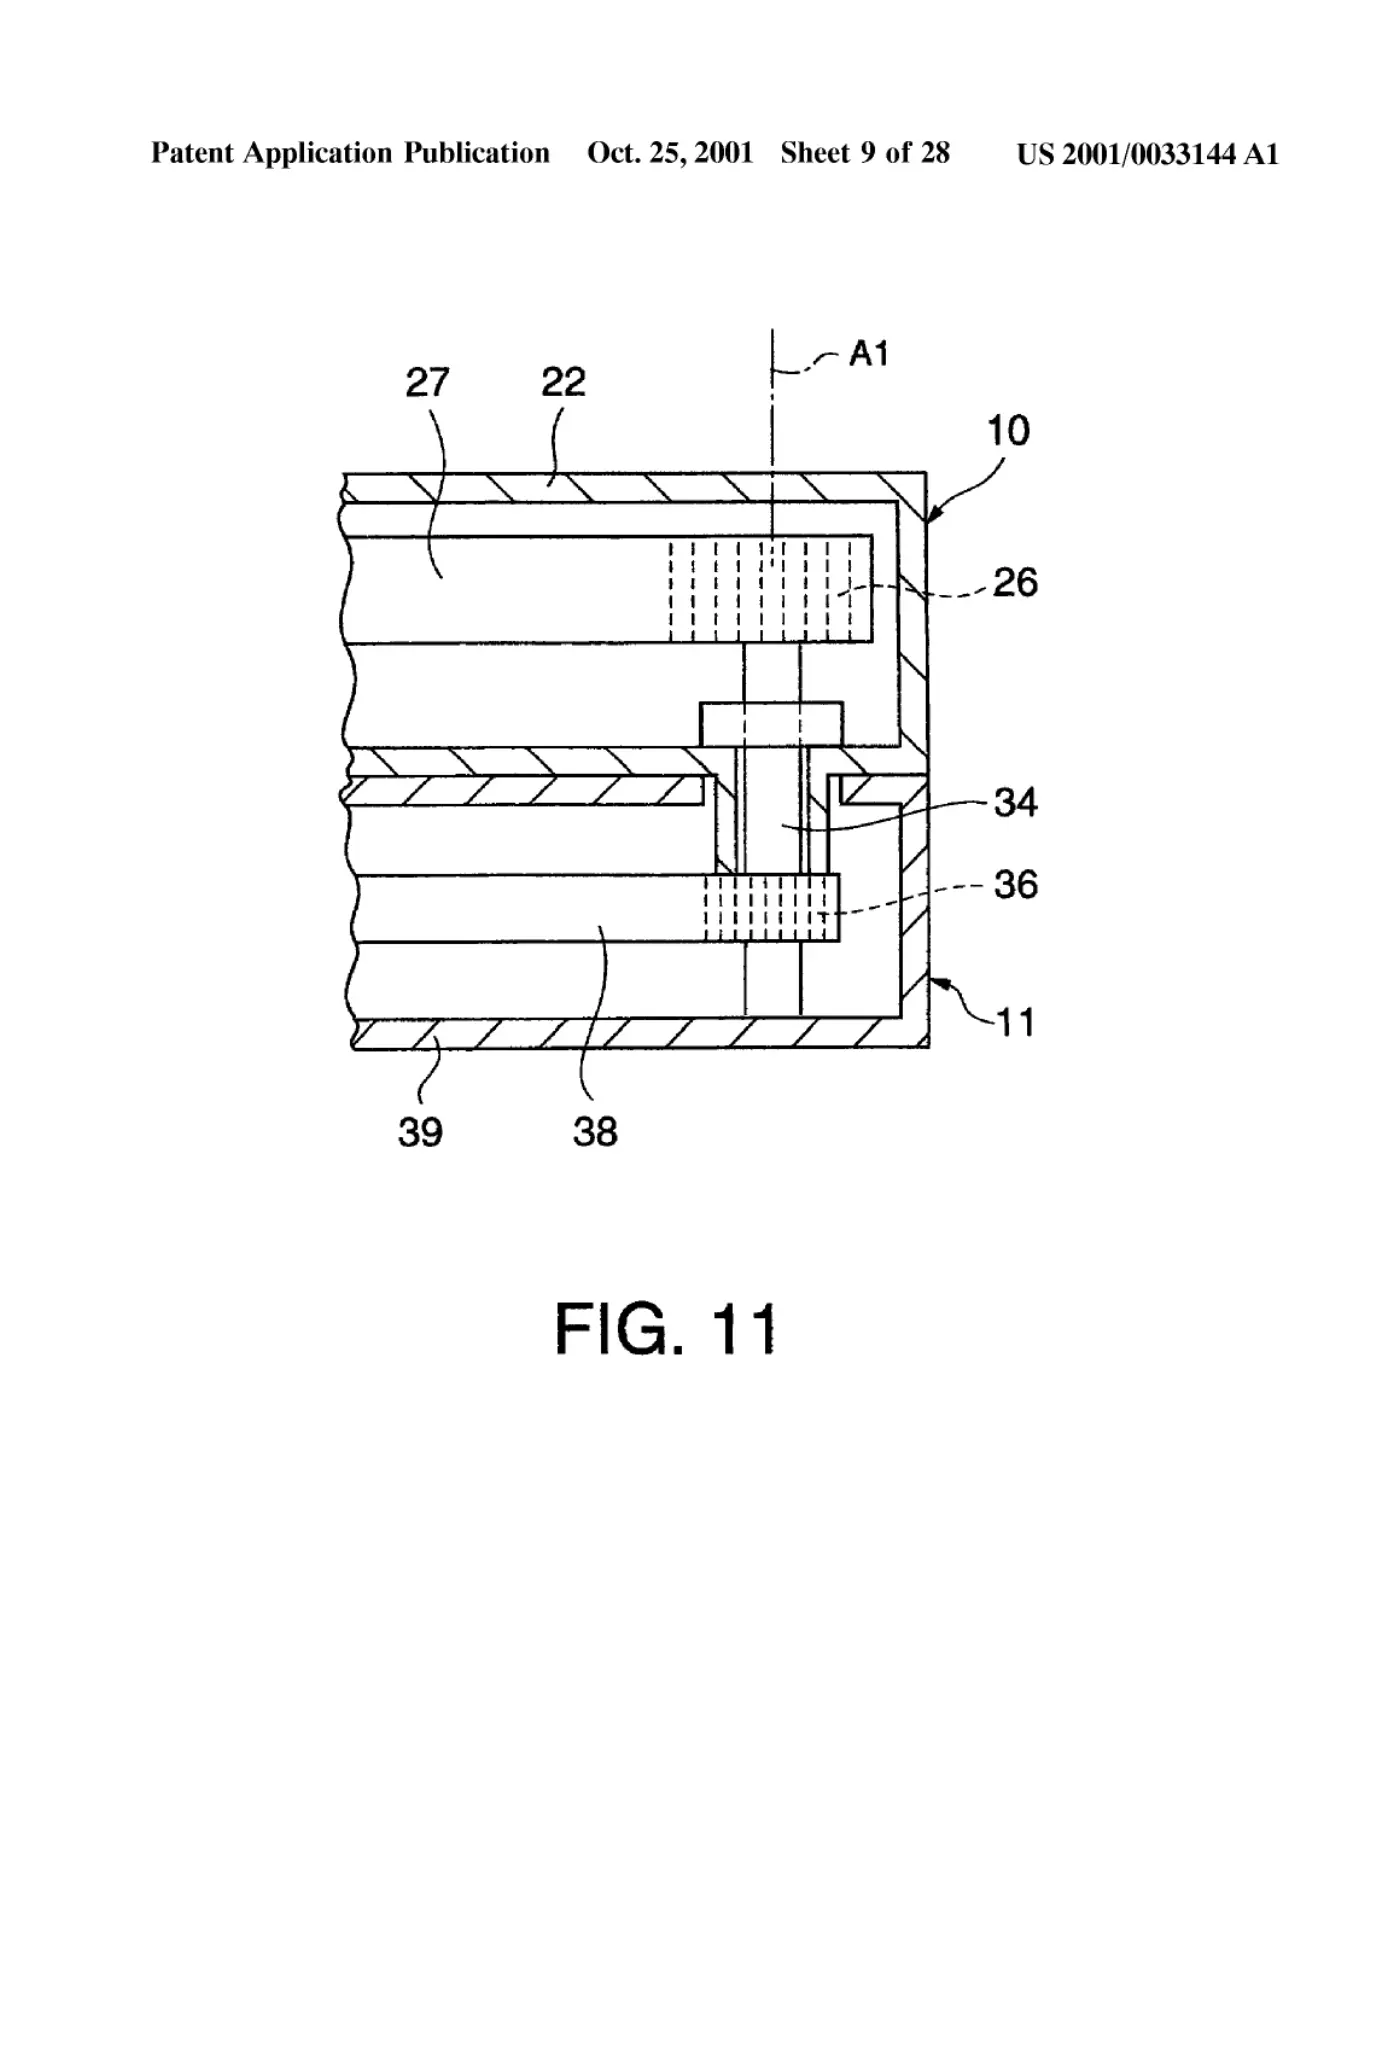
[0009]Sheet 9.
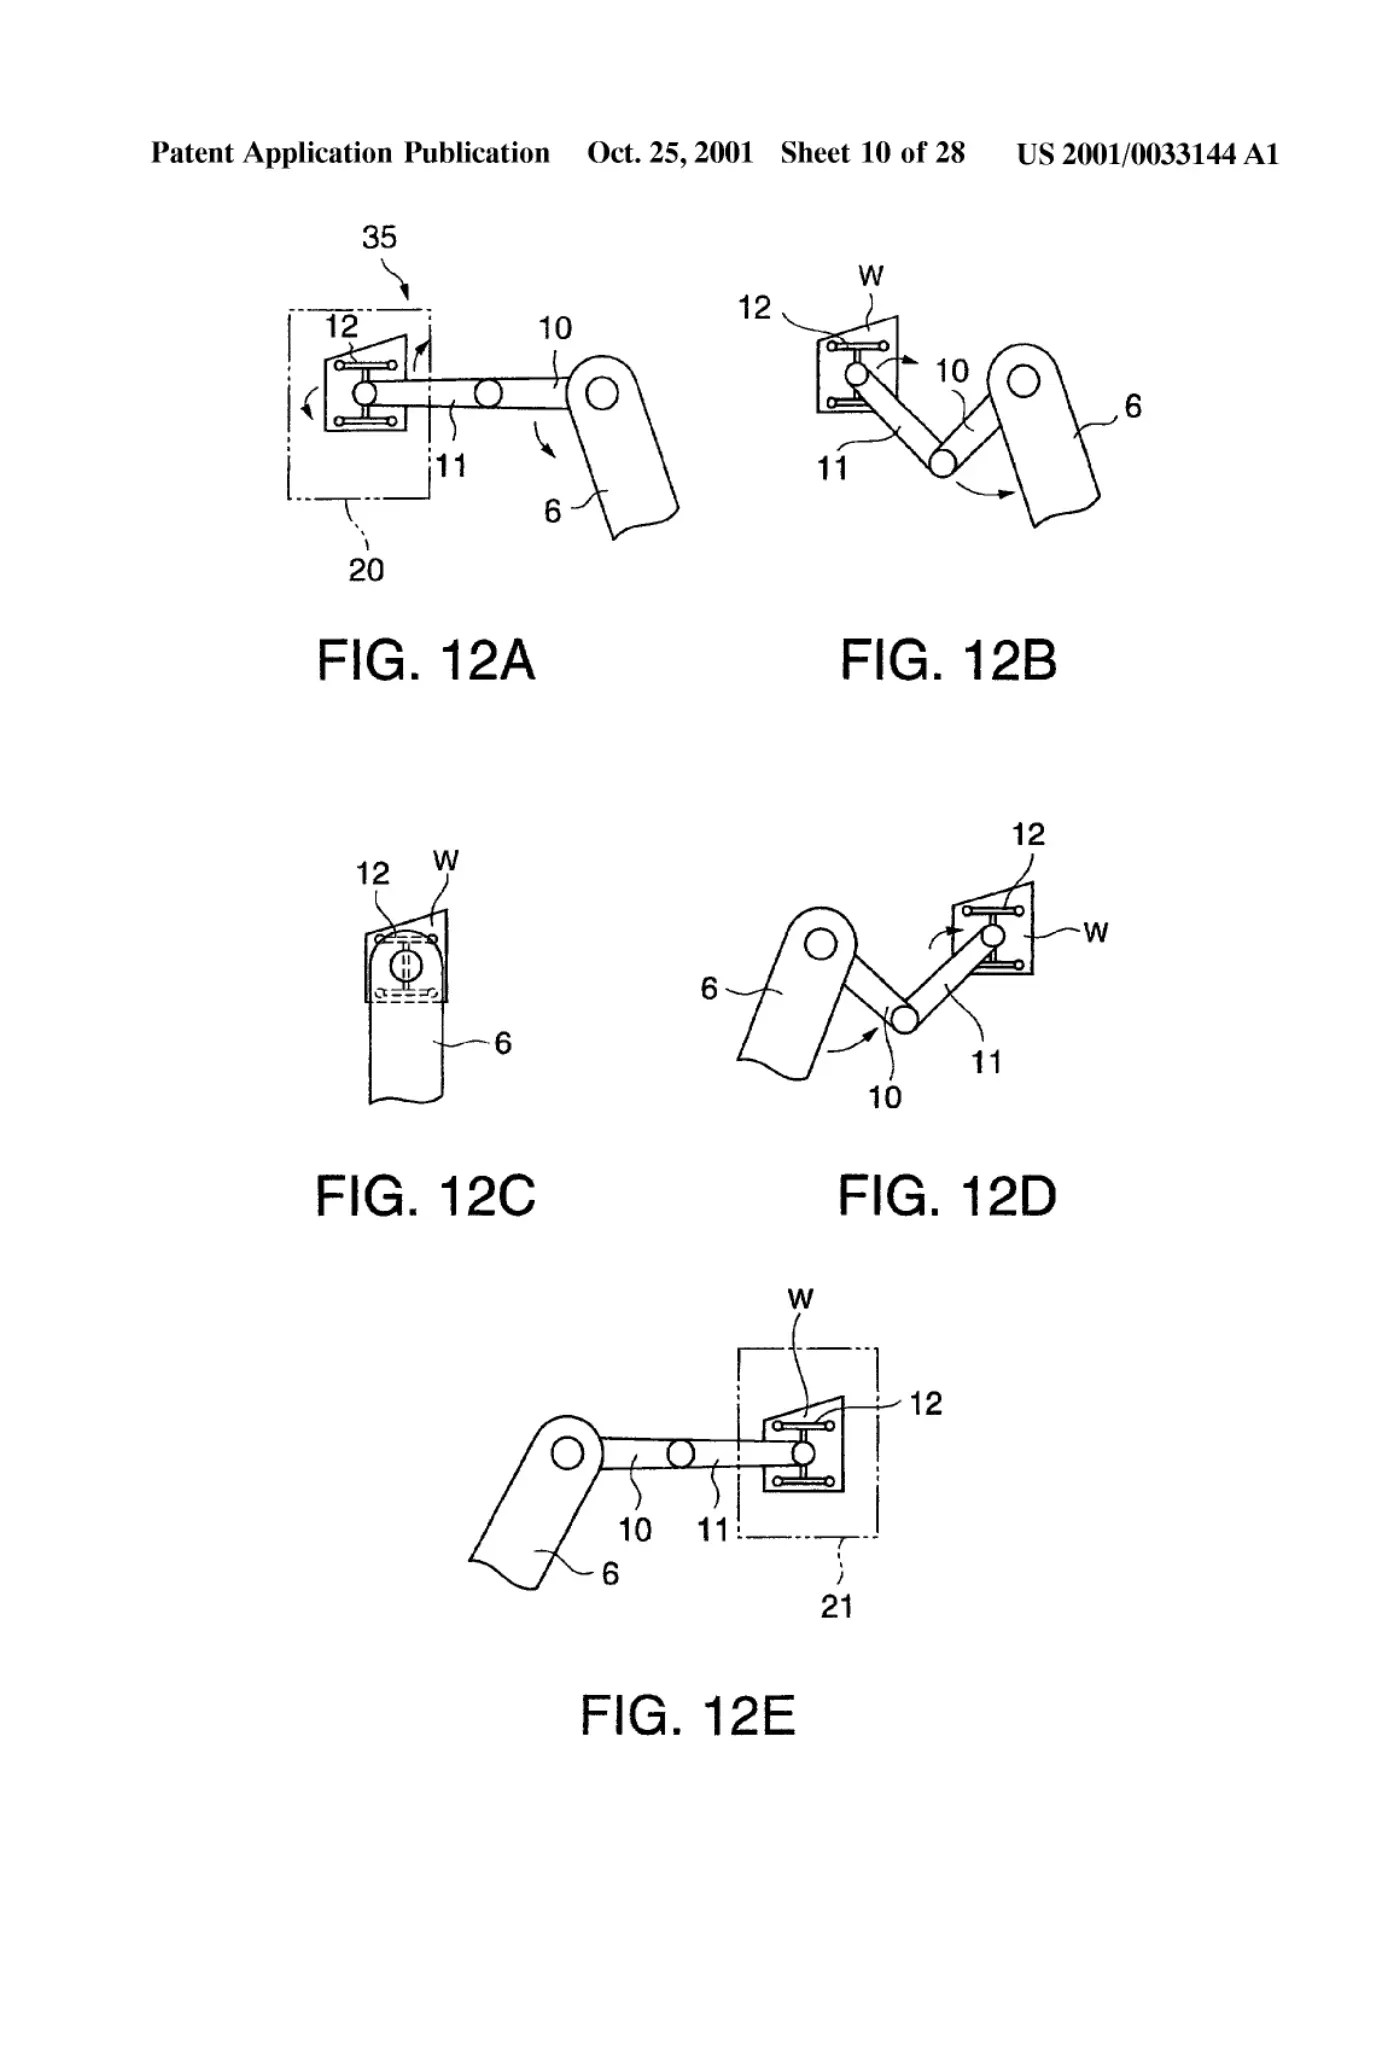
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003089, “Robot system,” published September 15, 2026 at 19:26:18 UTC, https://opentechnical.org/p/OT-2026-000003089.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.