OT-2026-000003306
Robot with cruciform geometry
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003306
- Classification
- Robotics & Automation › End Effectors
- Assignee
- UNIV CARNEGIE MELLON
- Original source
- US-5429009-A, the United States Patent and Trademark Office, 4 July 1995
- Document SHA-256
- b56f39c31e0ddb673c5309b8c9d10d951ed140dfa311b08b740739647a9f3d7f
A movable robot for performing tasks upon and traversing a work surface. The robot having a first support means having a longitudinal axis. The first support means have first gripping means extending therefrom for detachable adhering the first support means to the work surface. The robot further having at least one second support means movably coupled to the first support means. Respective second gripping means extend from each second support means for detachable adhering the second support means to the work surface. The first and second gripping means are capable of being moved relative to one another both in a direction parallel to the longitudinal axis and along a line that intersects the longitudinal axis. At least one tool is attached to one or more of the first and second support means.
Abstract
A movable robot for performing tasks upon and traversing a work surface. The robot having a first support means having a longitudinal axis. The first support means have first gripping means extending therefrom for detachable adhering the first support means to the work surface. The robot further having at least one second support means movably coupled to the first support means. Respective second gripping means extend from each second support means for detachable adhering the second support means to the work surface. The first and second gripping means are capable of being moved relative to one another both in a direction parallel to the longitudinal axis and along a line that intersects the longitudinal axis. At least one tool is attached to one or more of the first and second support means.
1. Drawings
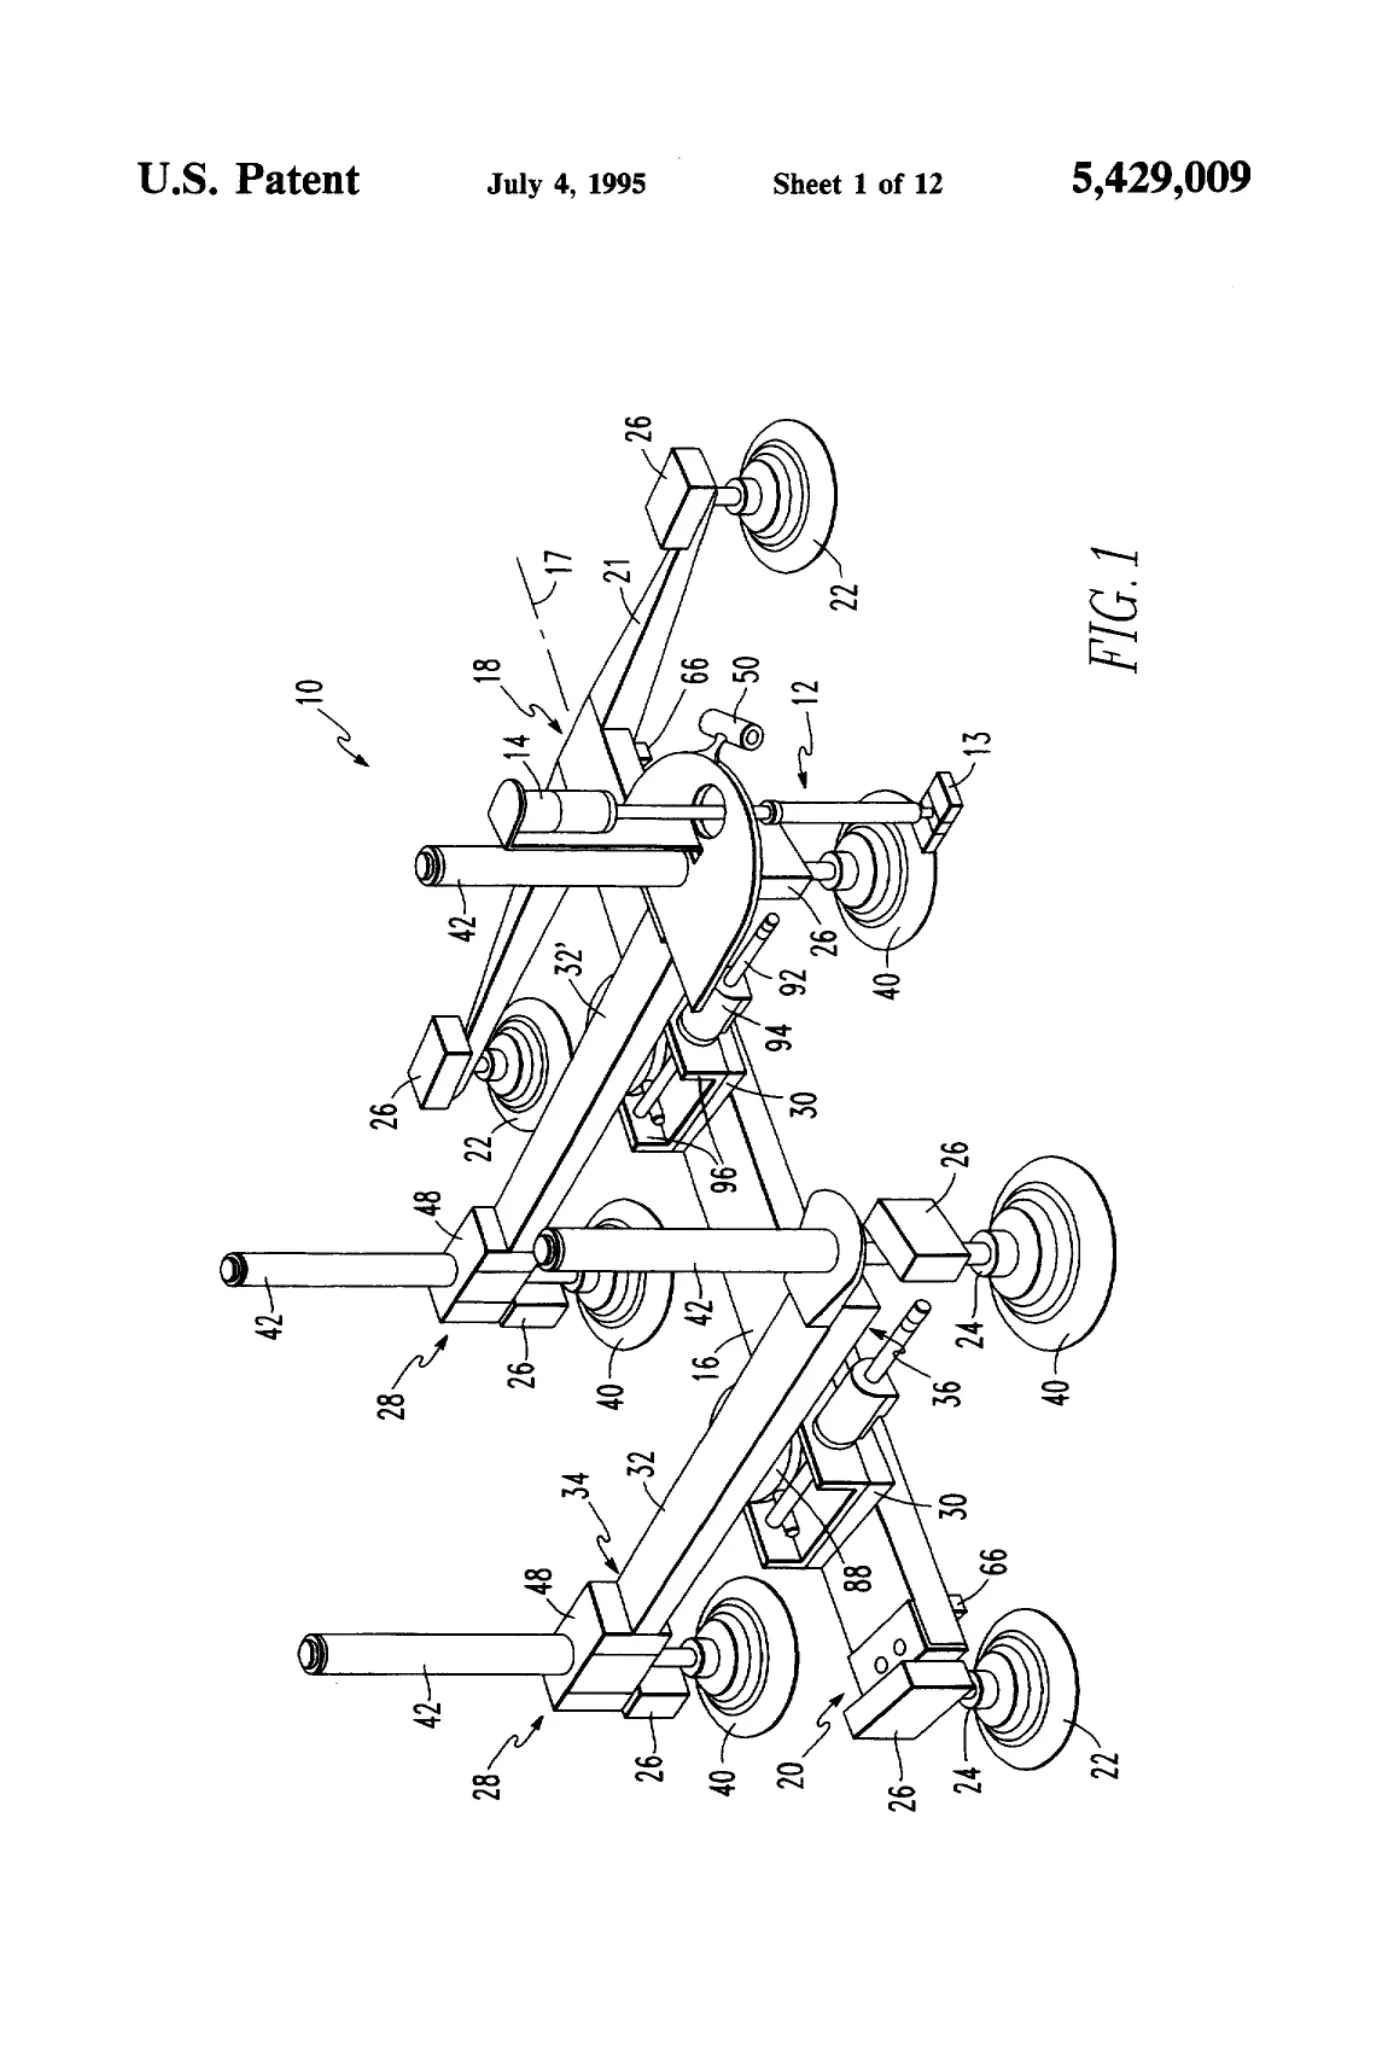
[0001]Sheet 1.
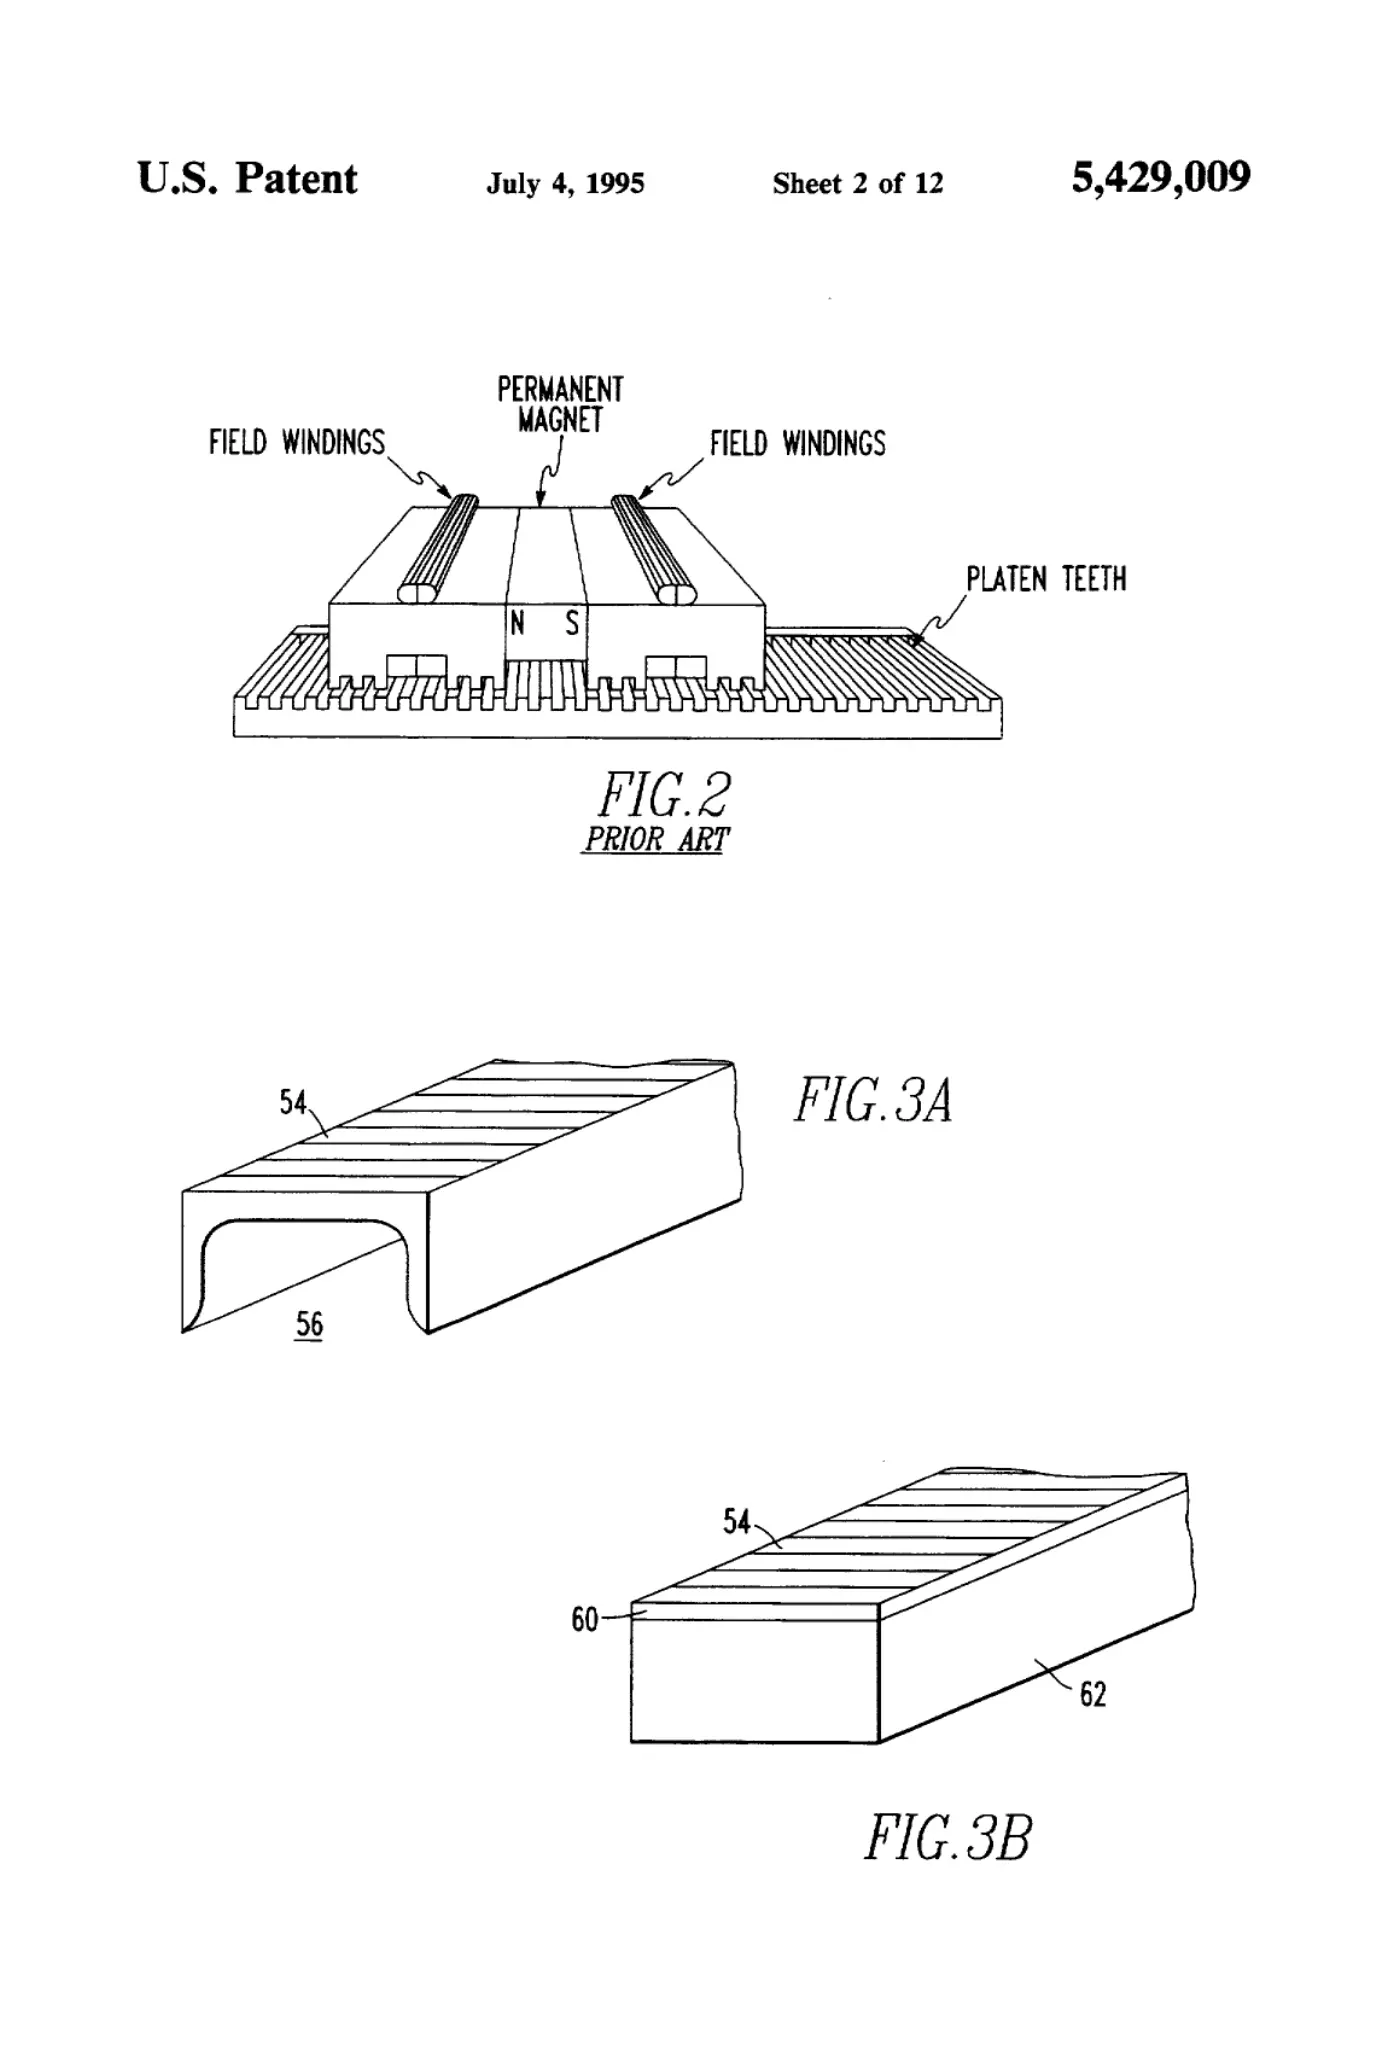
[0002]Sheet 2.
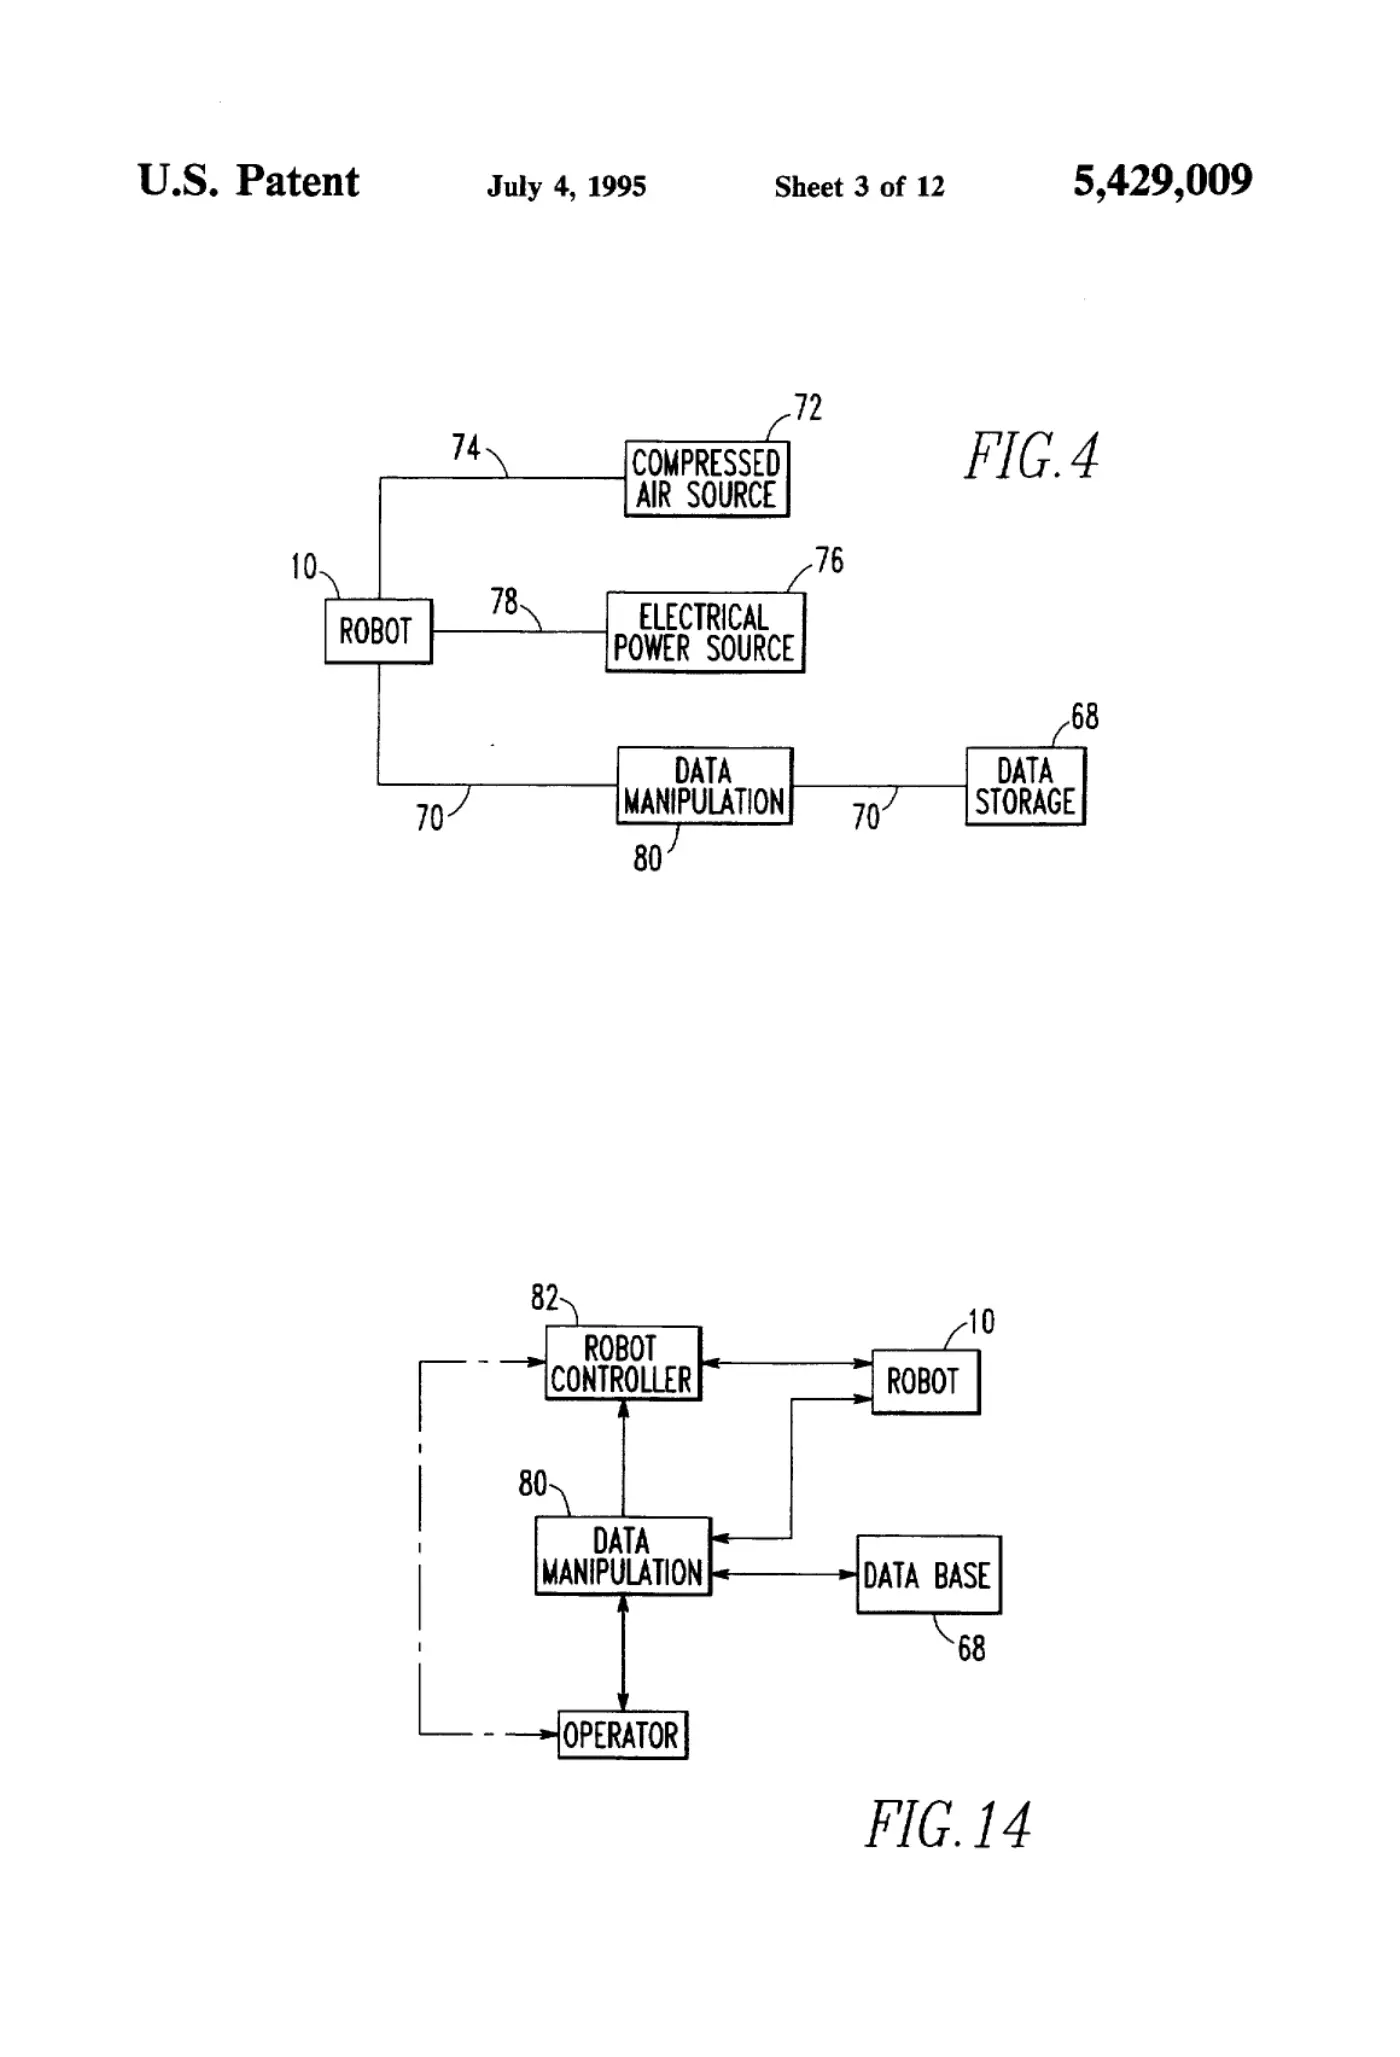
[0003]Sheet 3.
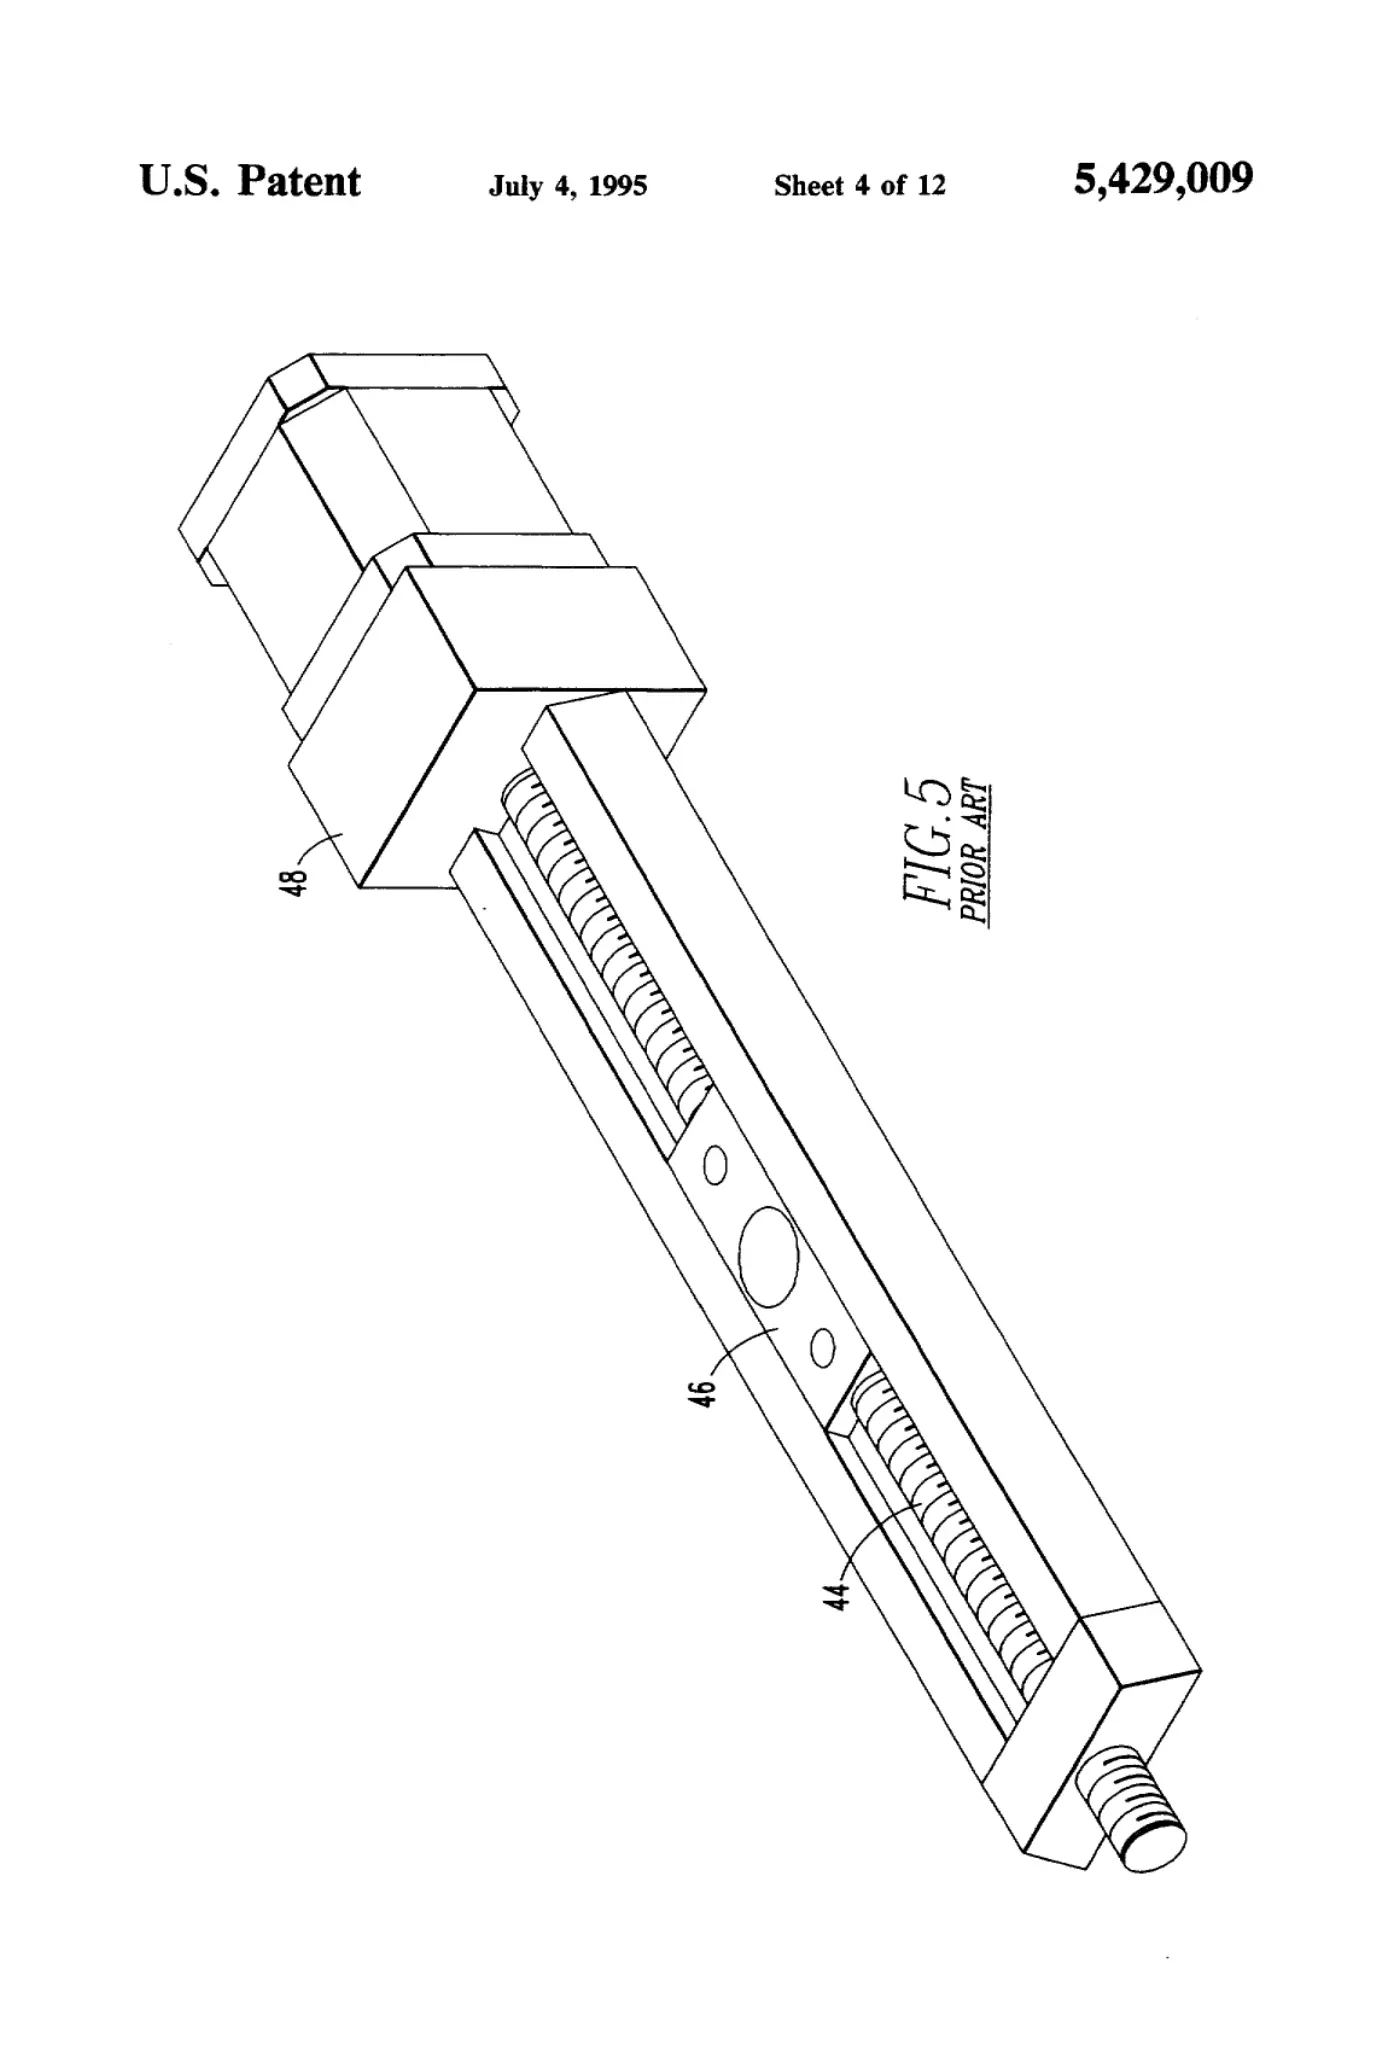
[0004]Sheet 4.
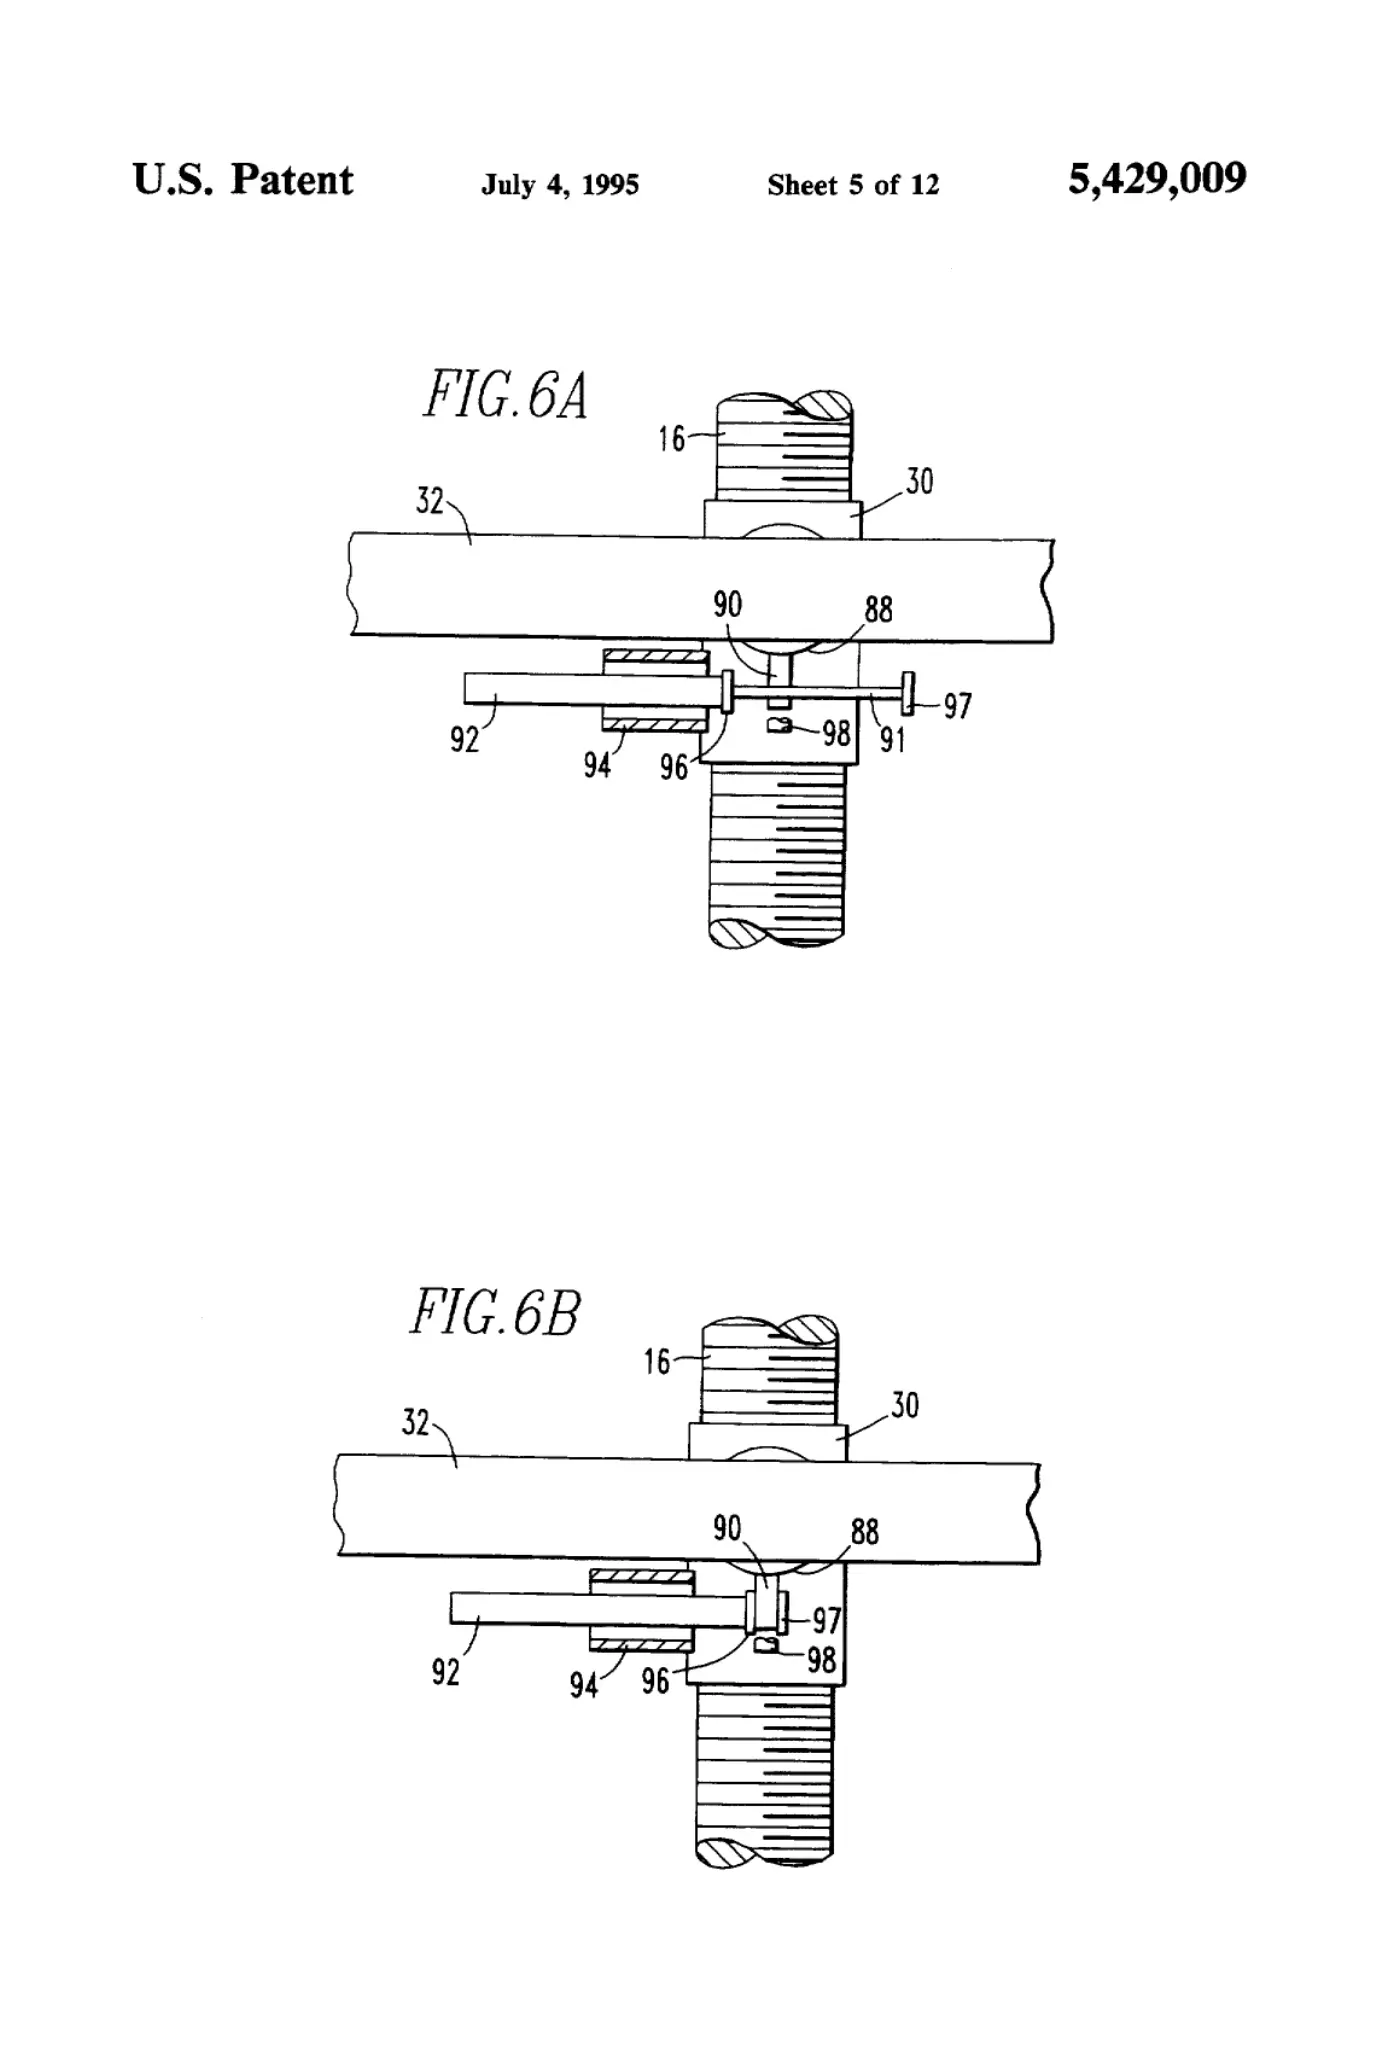
[0005]Sheet 5.
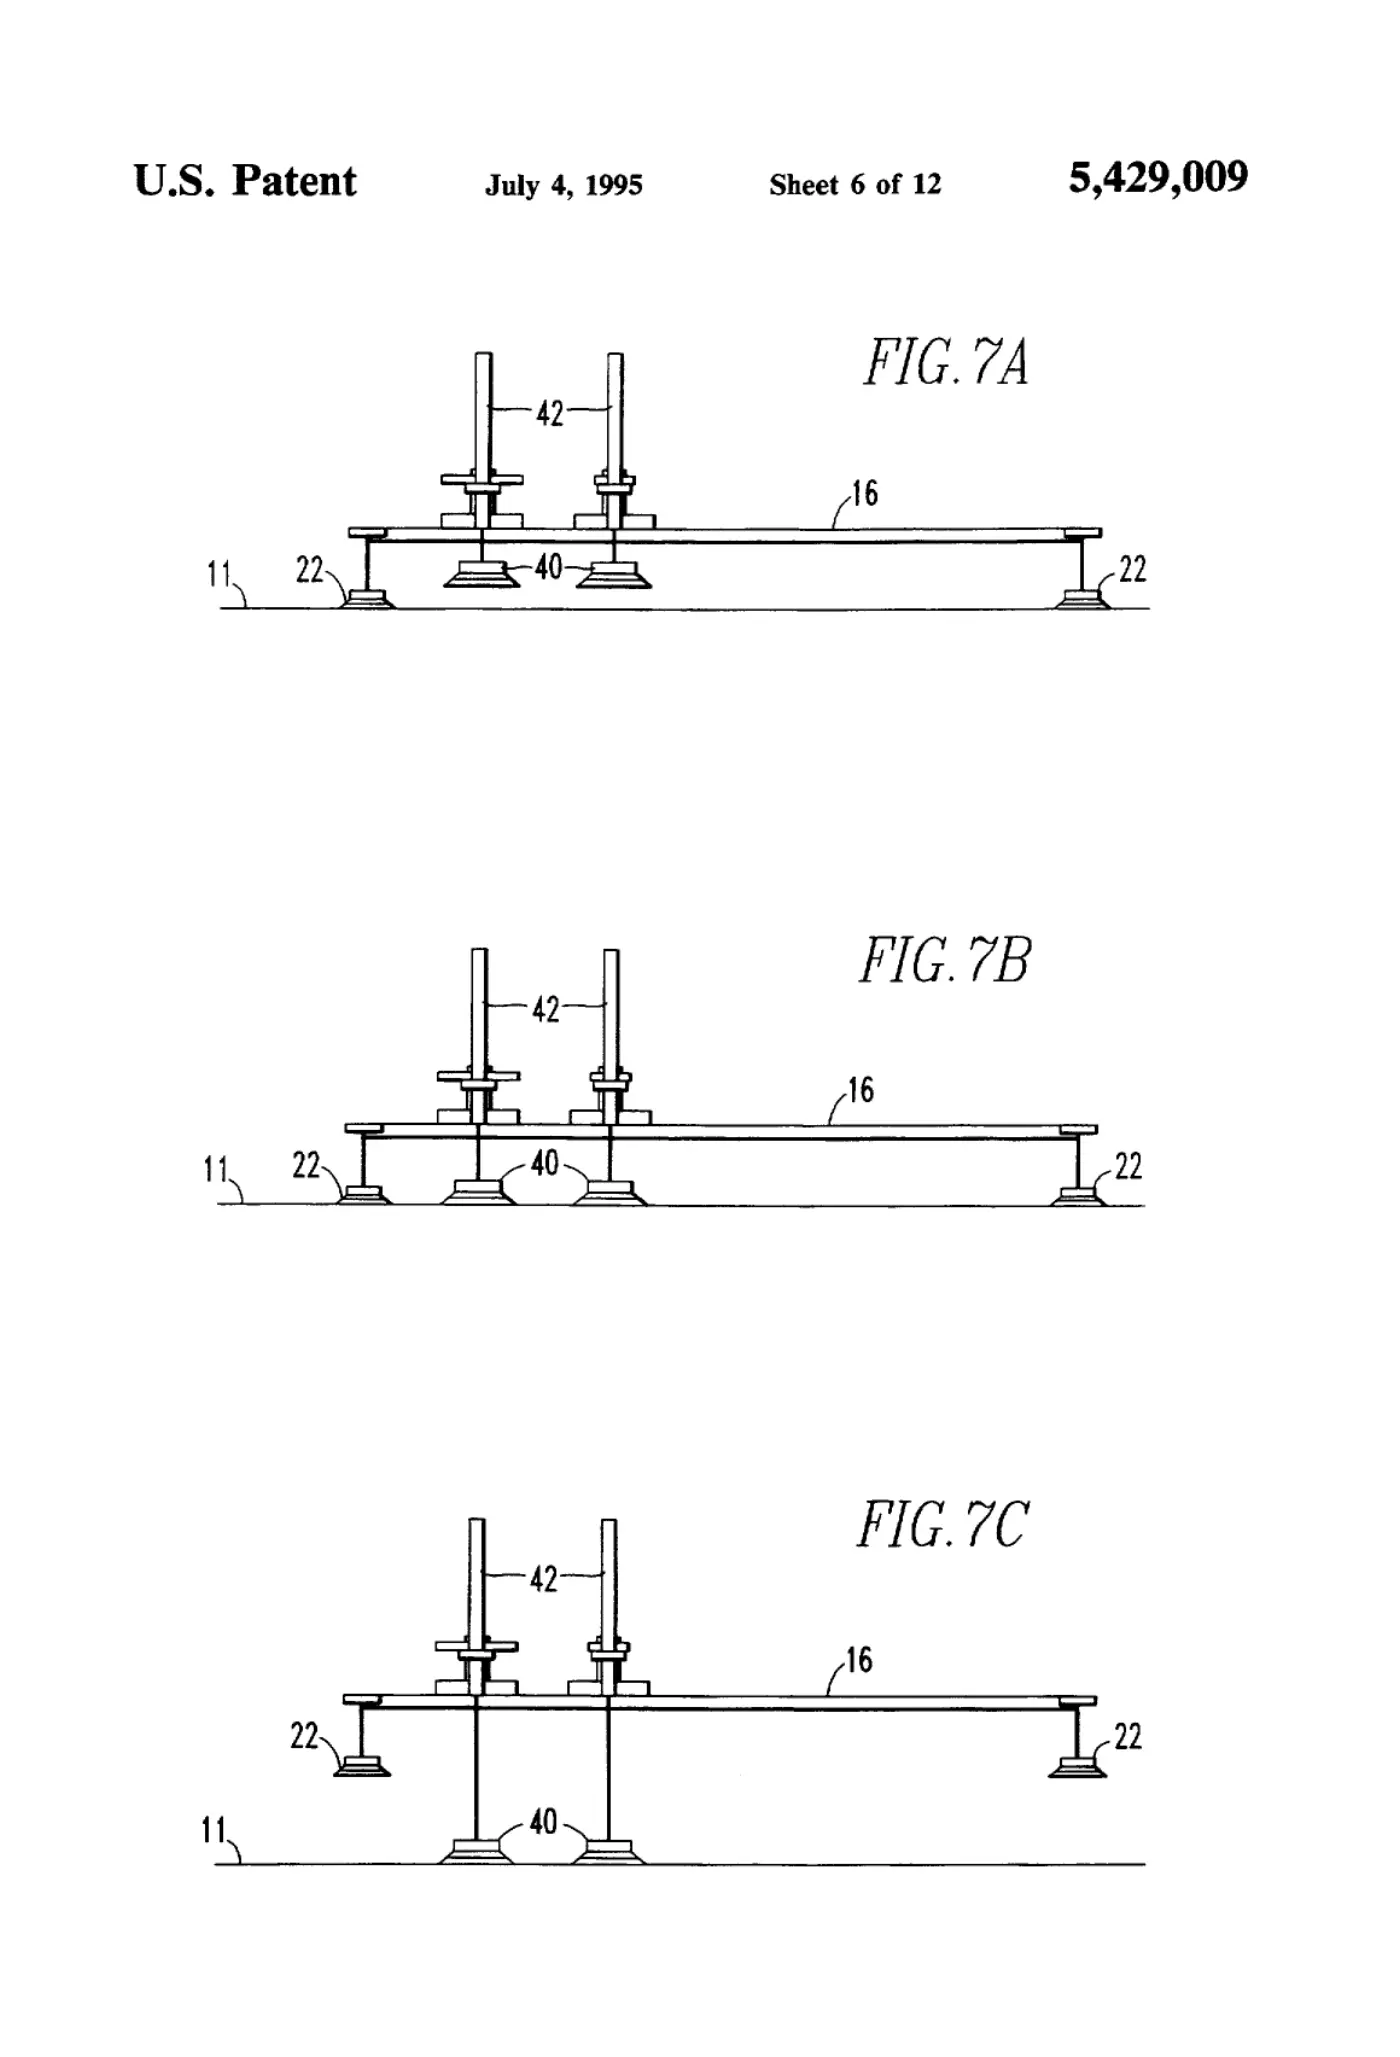
[0006]Sheet 6.
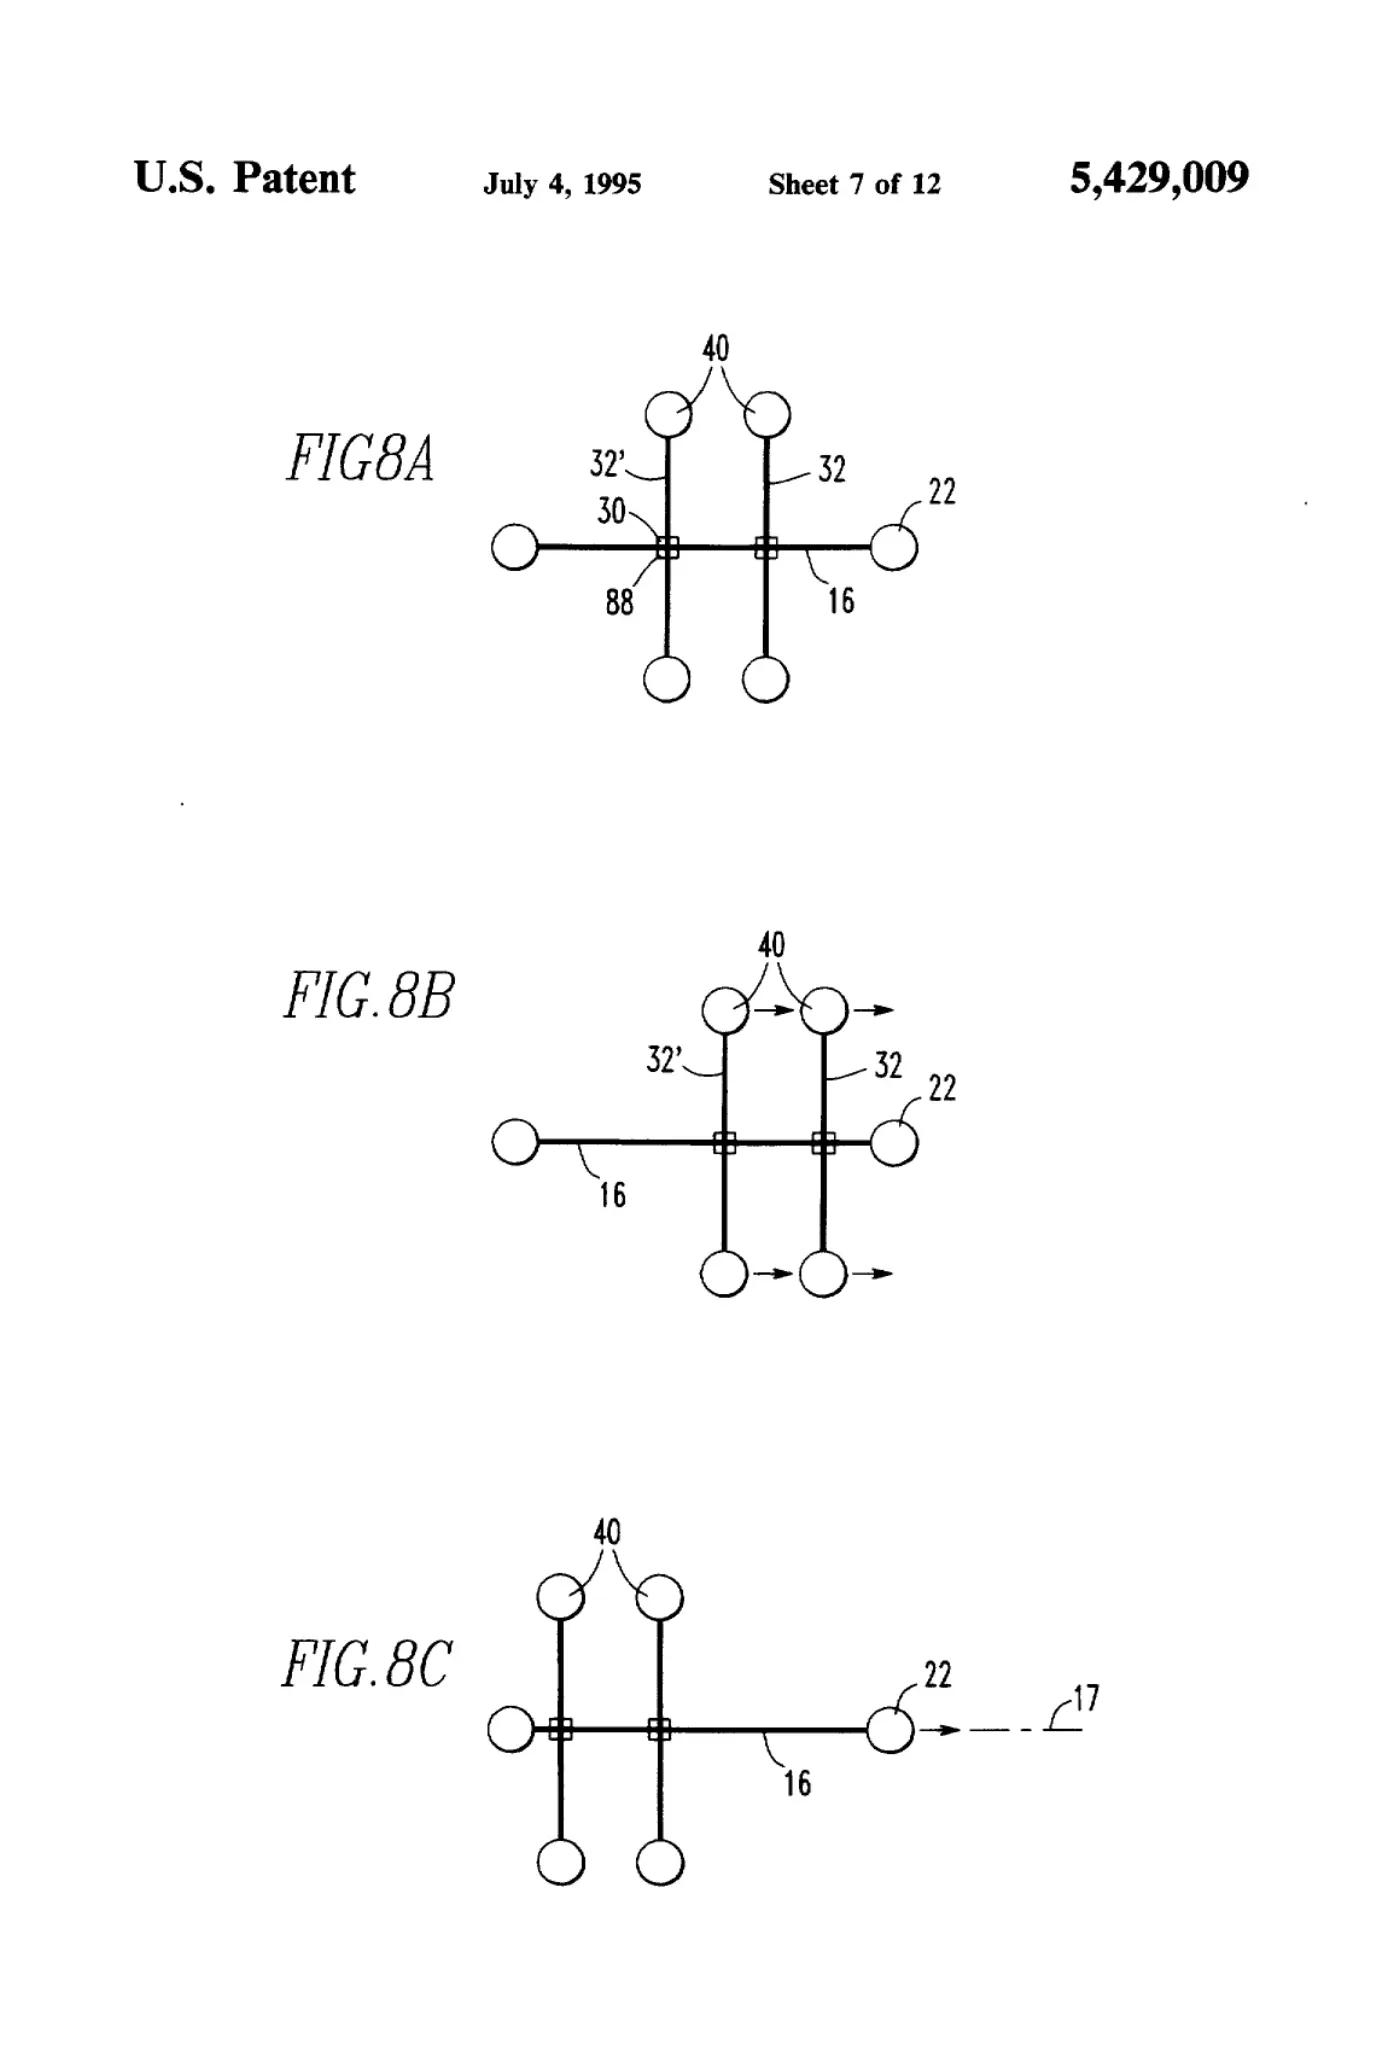
[0007]Sheet 7.
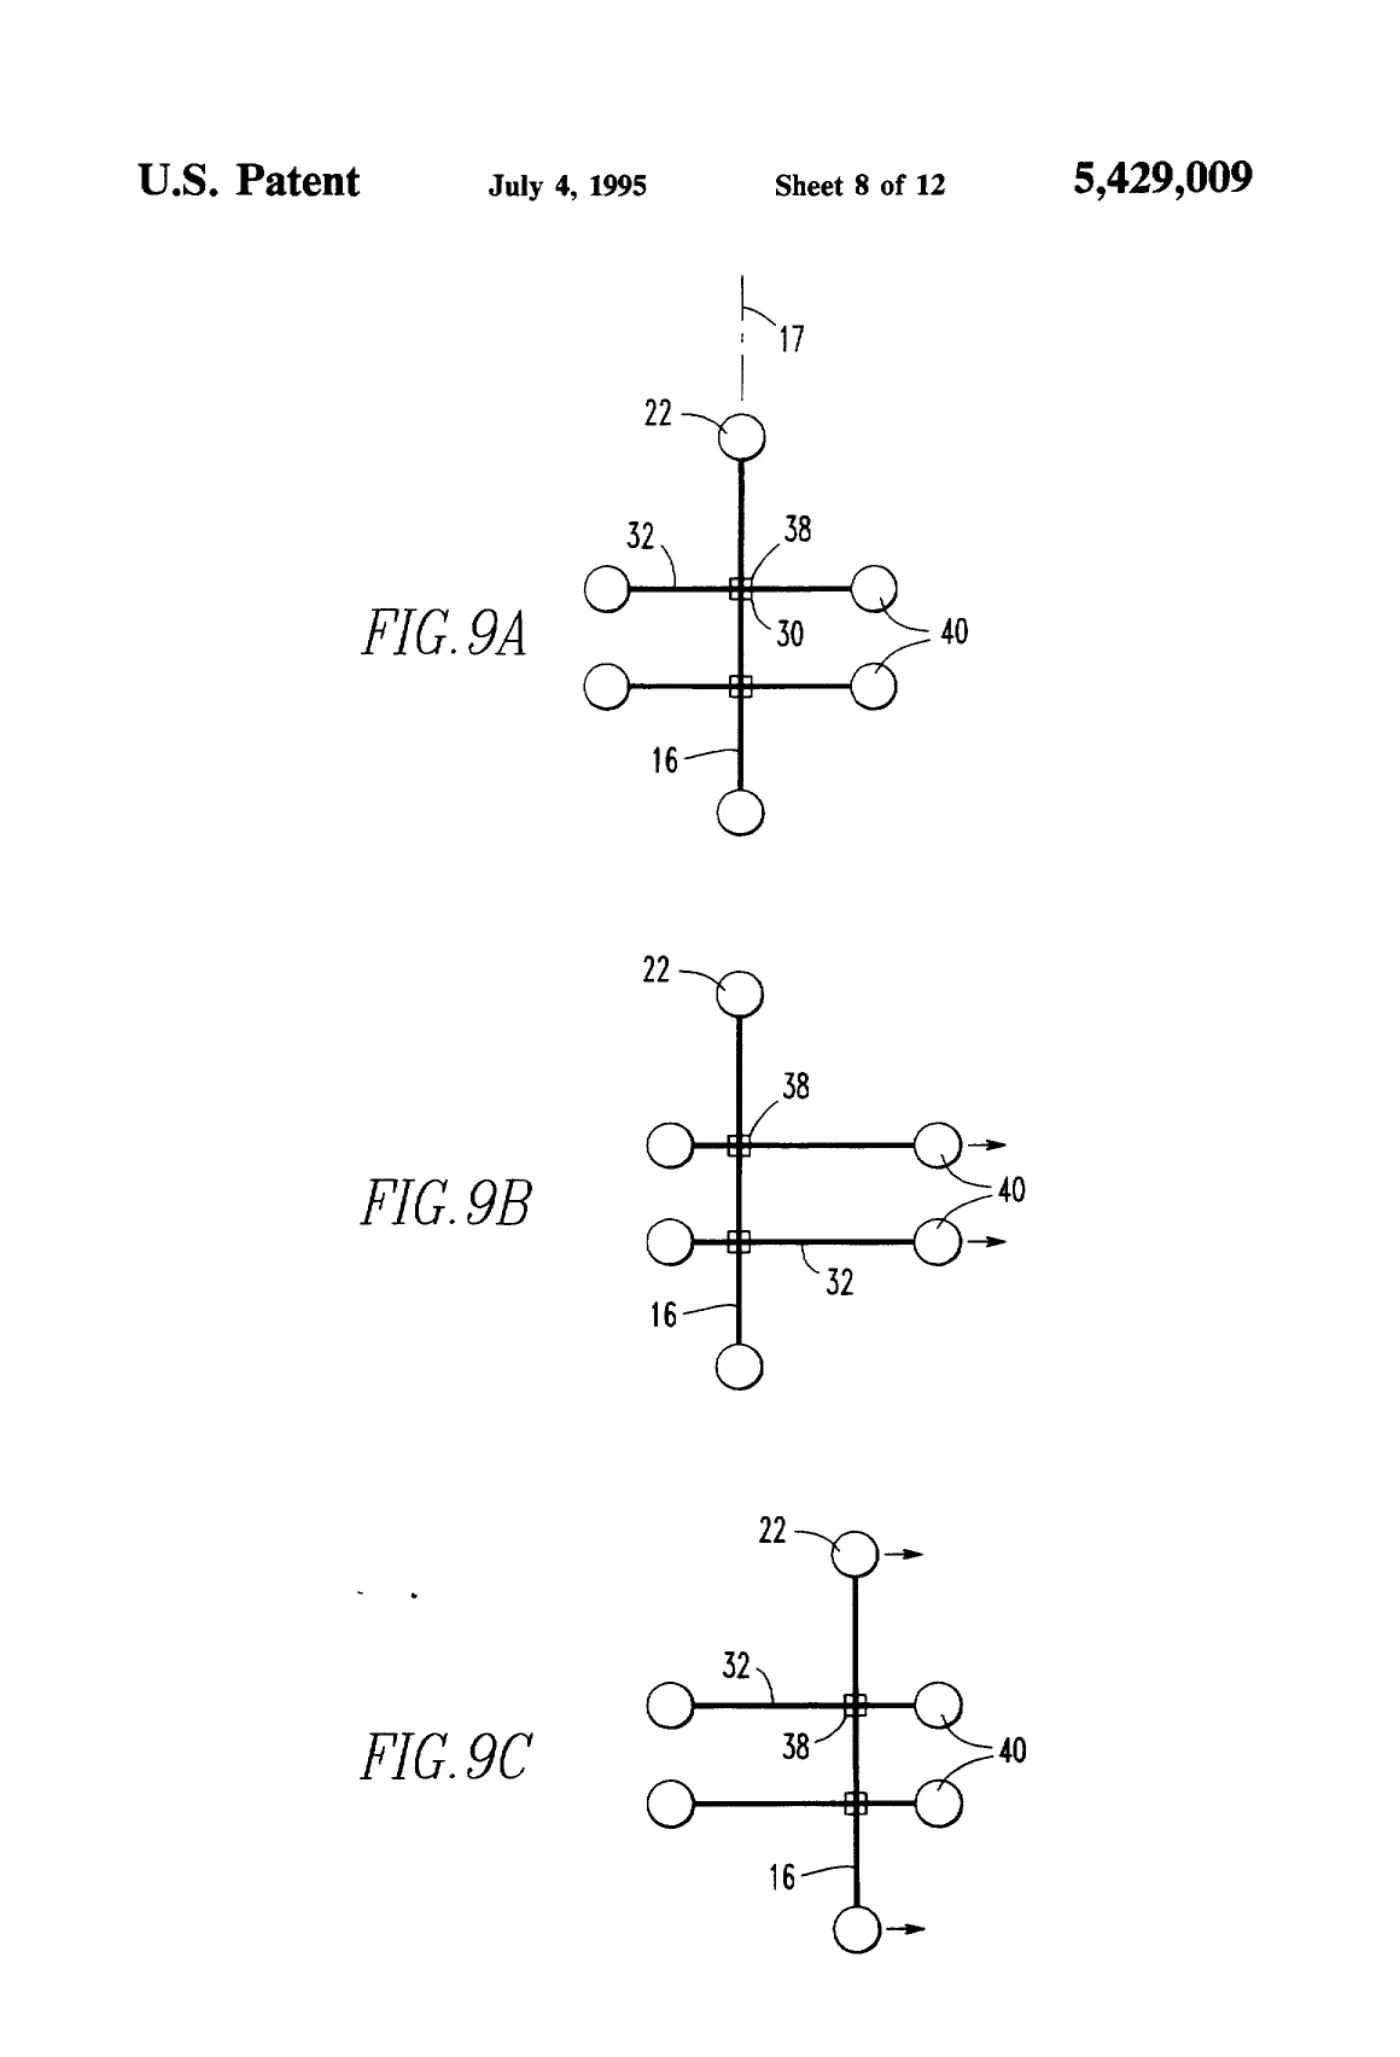
[0008]Sheet 8.
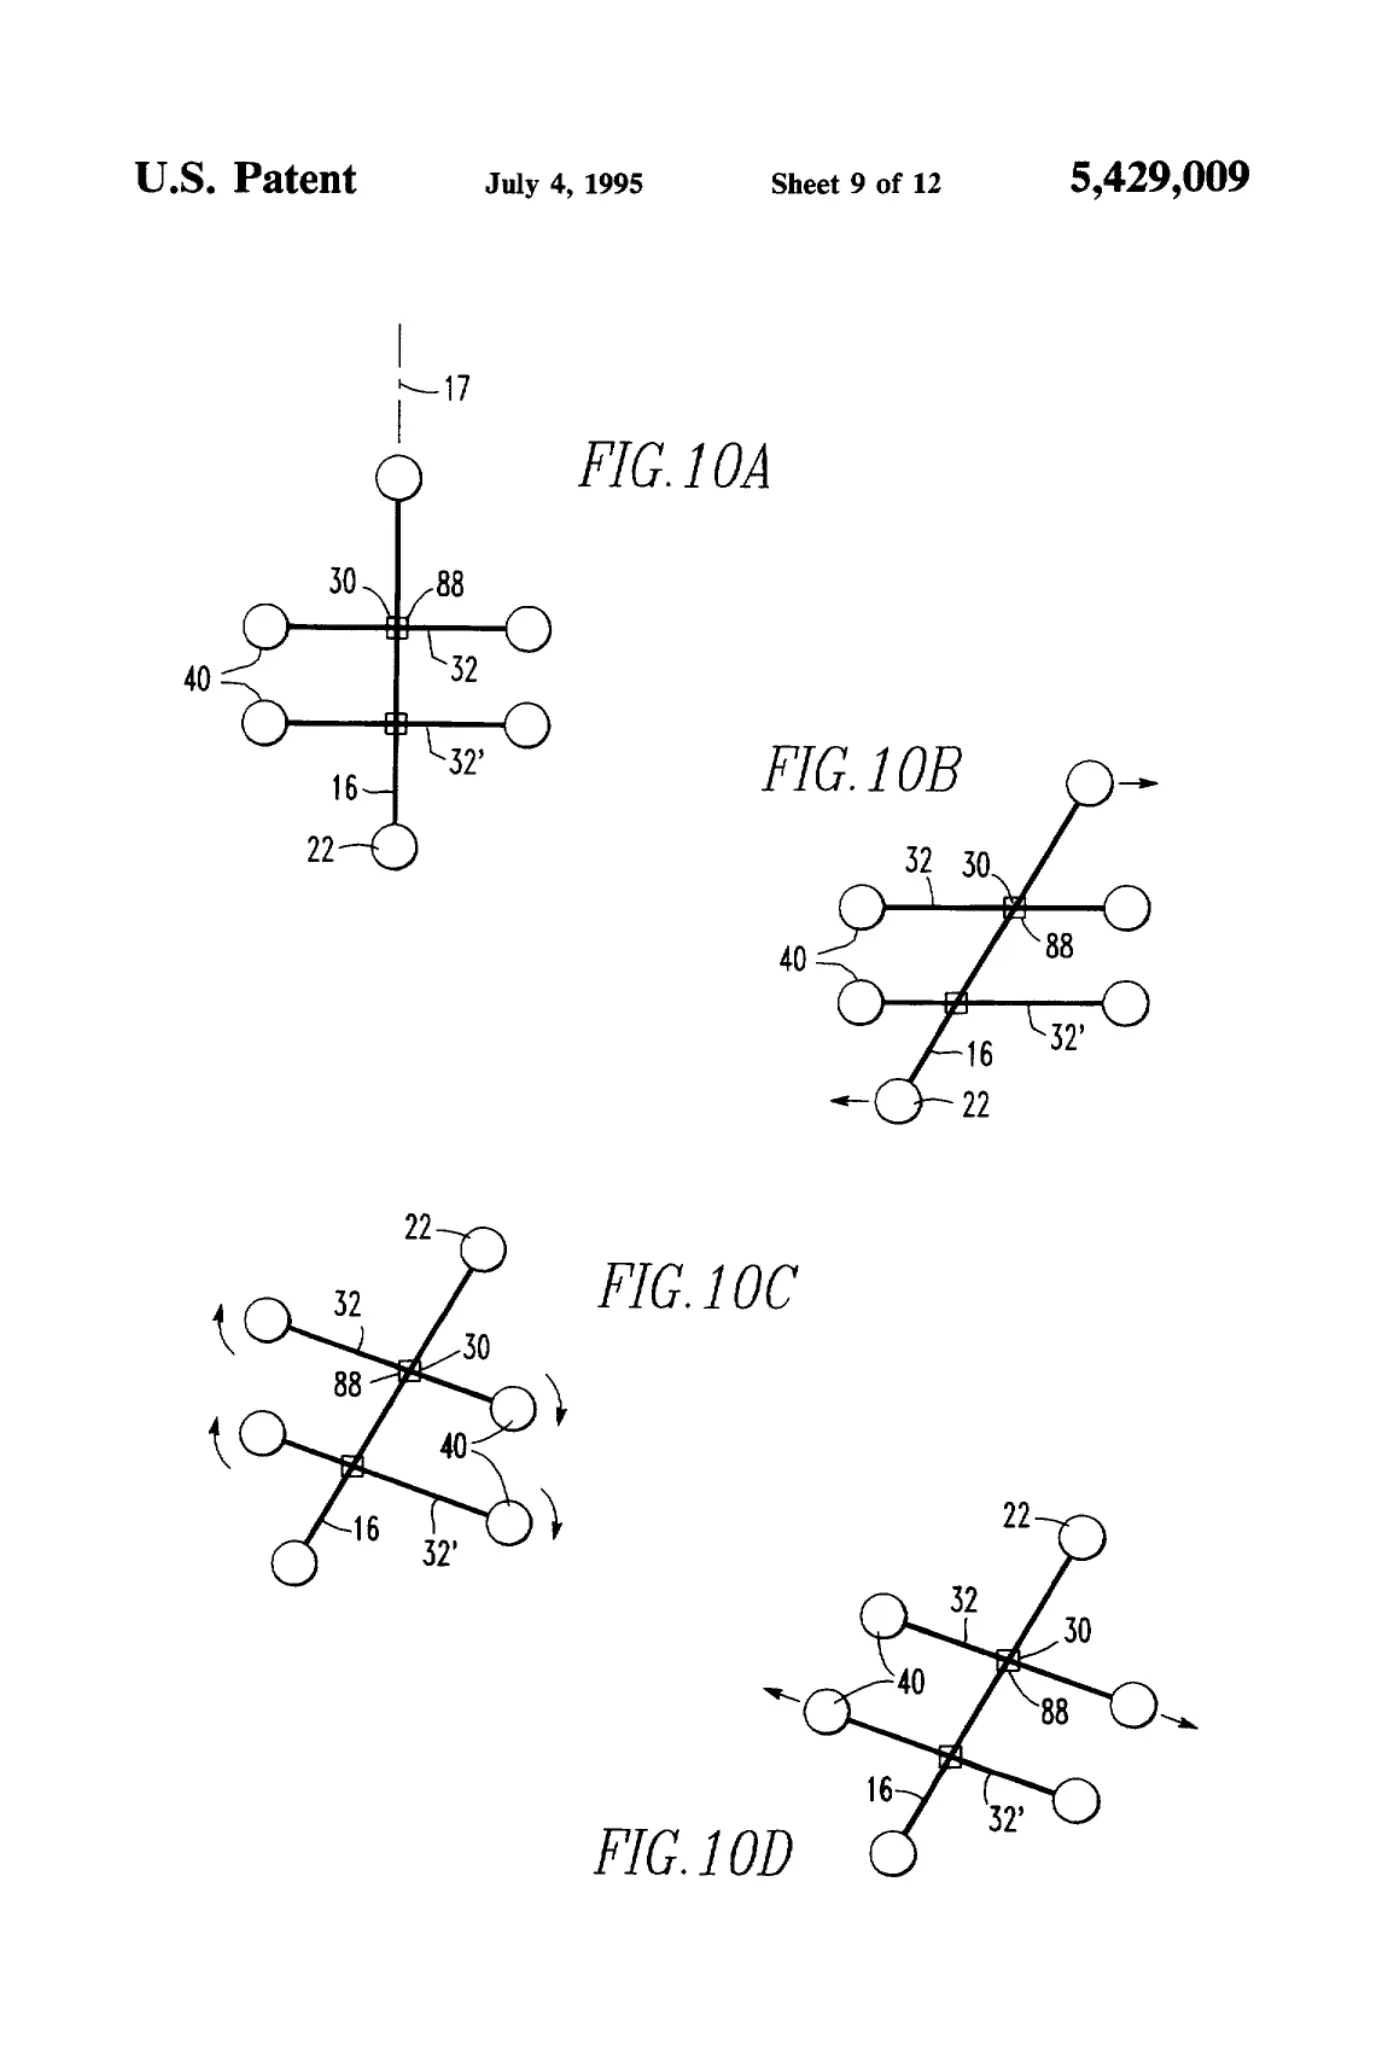
[0009]Sheet 9.
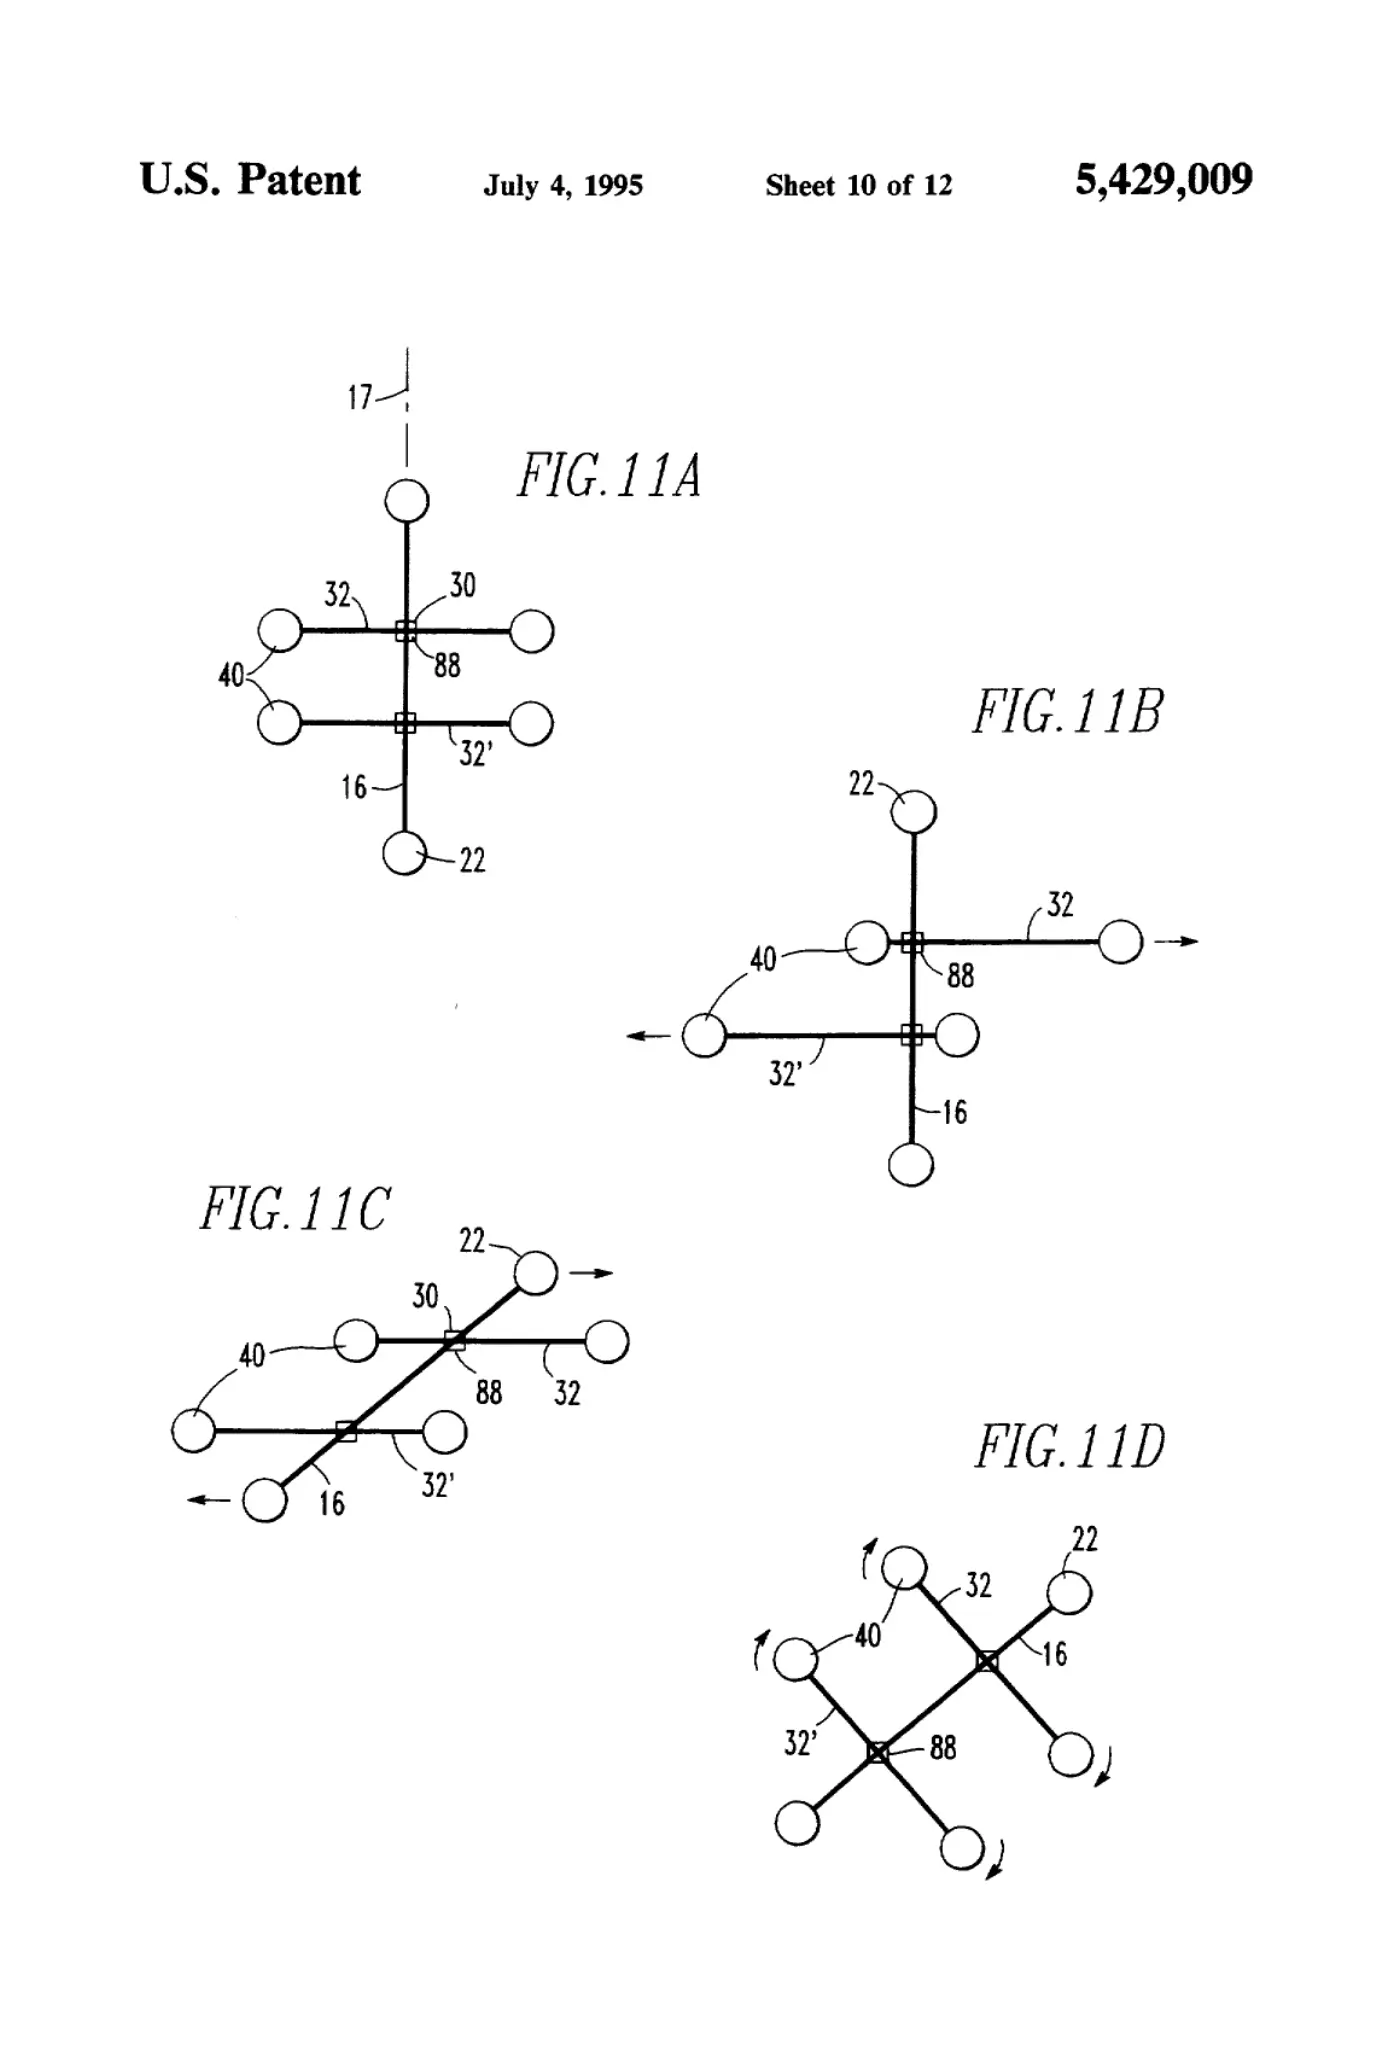
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003306, “Robot with cruciform geometry,” published September 15, 2026 at 20:06:32 UTC, https://opentechnical.org/p/OT-2026-000003306.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.