OT-2026-000003318
Suction type robot hand
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003318
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- IWATA HITOSHI, SEKIGUCHI KAZUYA, TAGUCHI MASAO
- Assignee
- HOUSE FOOD INDUSTRIAL CO
- Original source
- US-5388879-A, the United States Patent and Trademark Office, 14 February 1995
- Document SHA-256
- f337106c5f8fc85d61e8246550d063e5e79f6630e9f4f72bb9de7de807507fb8
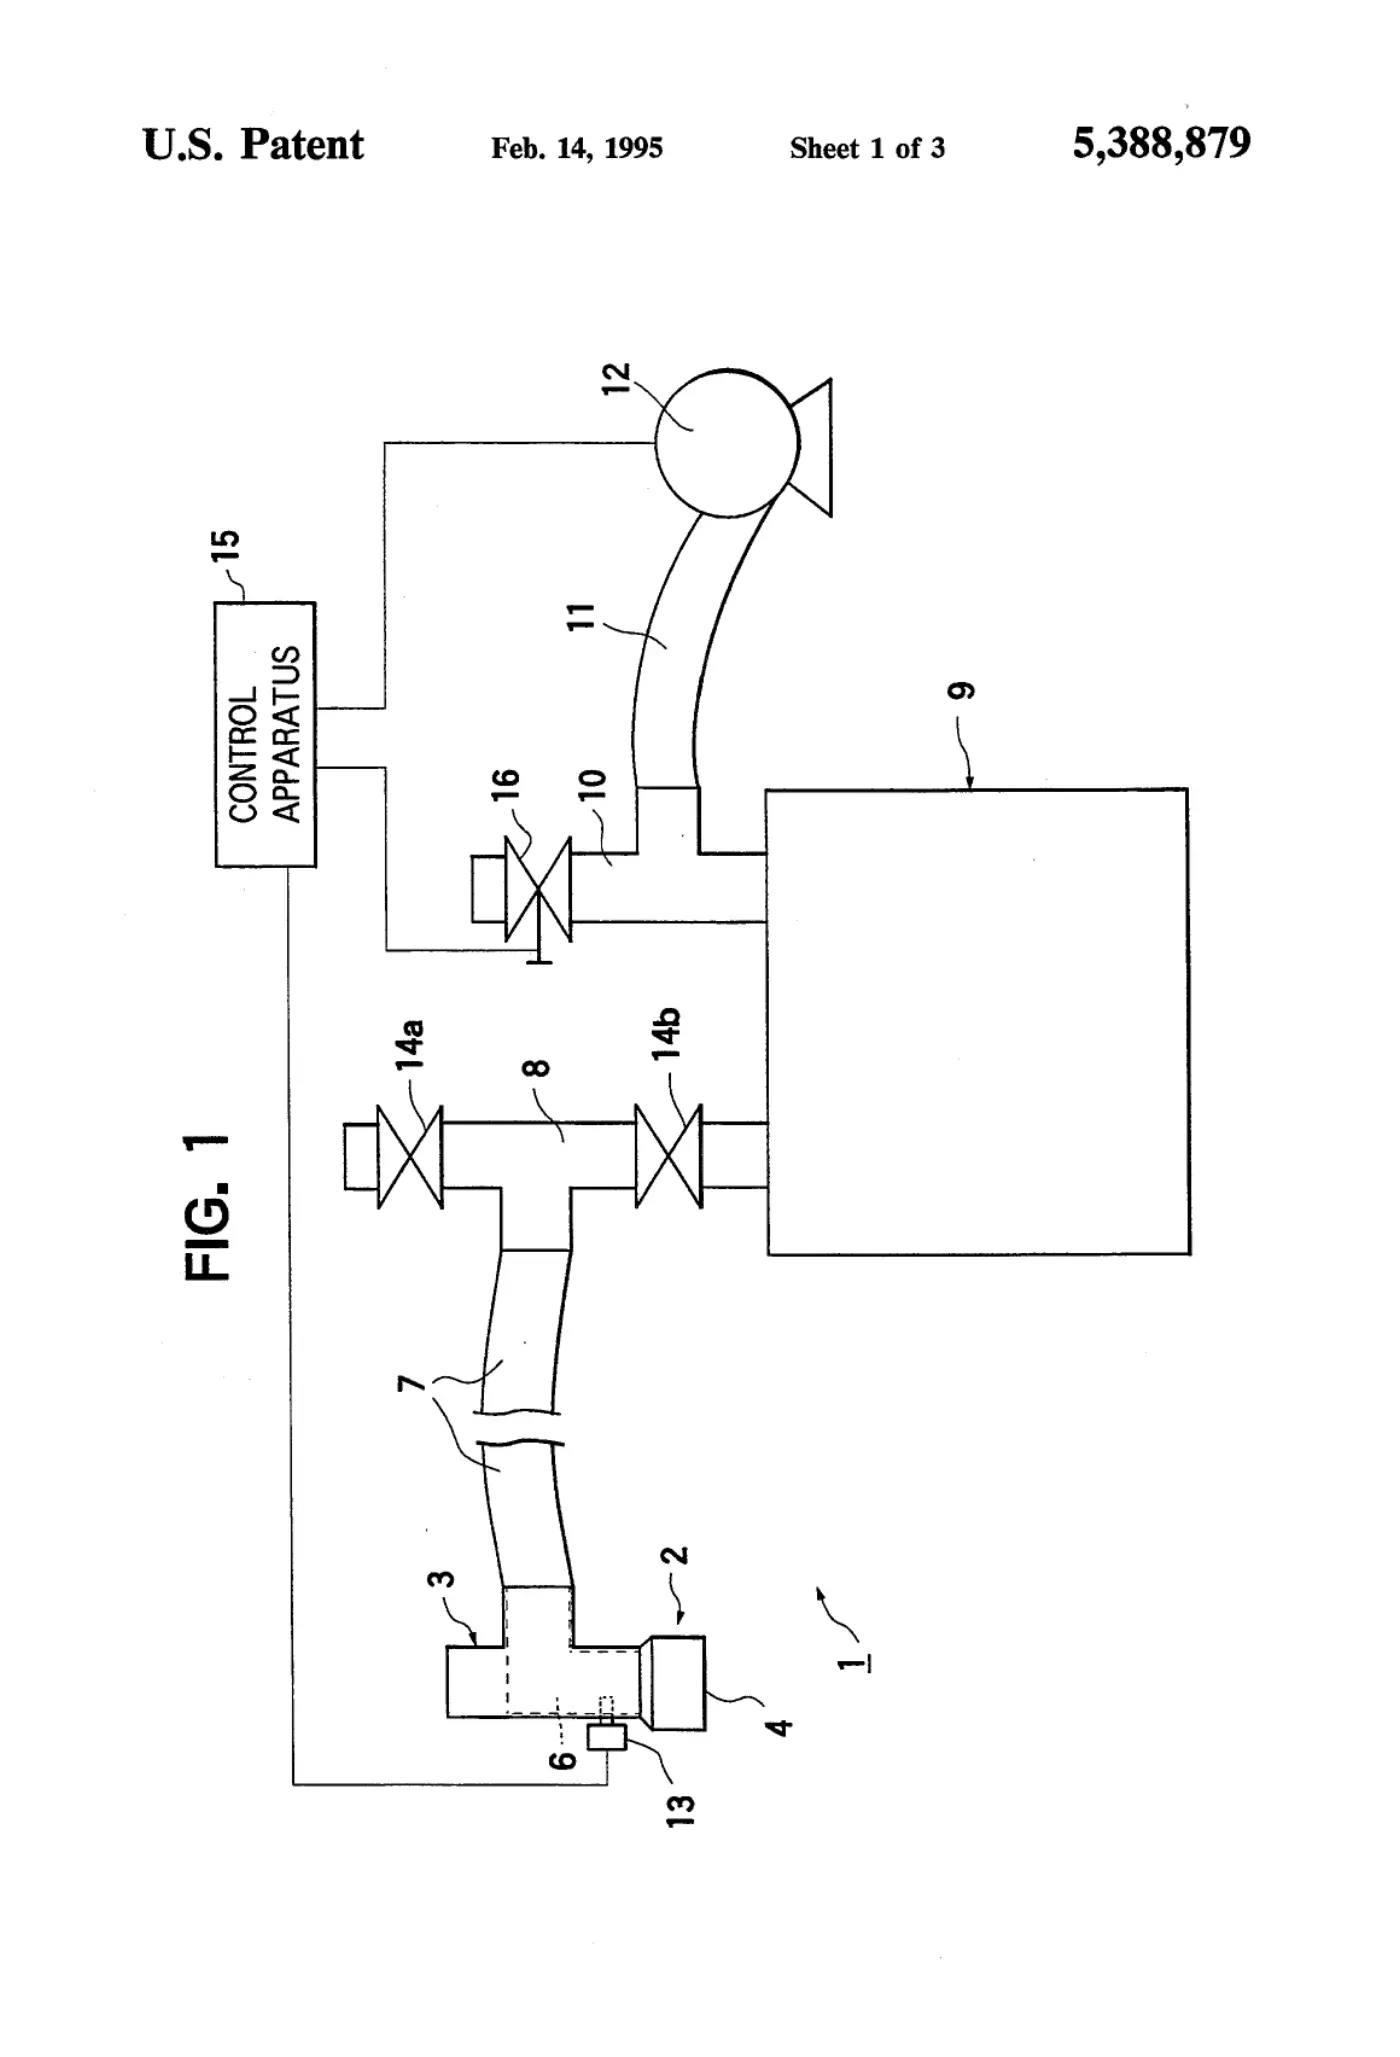
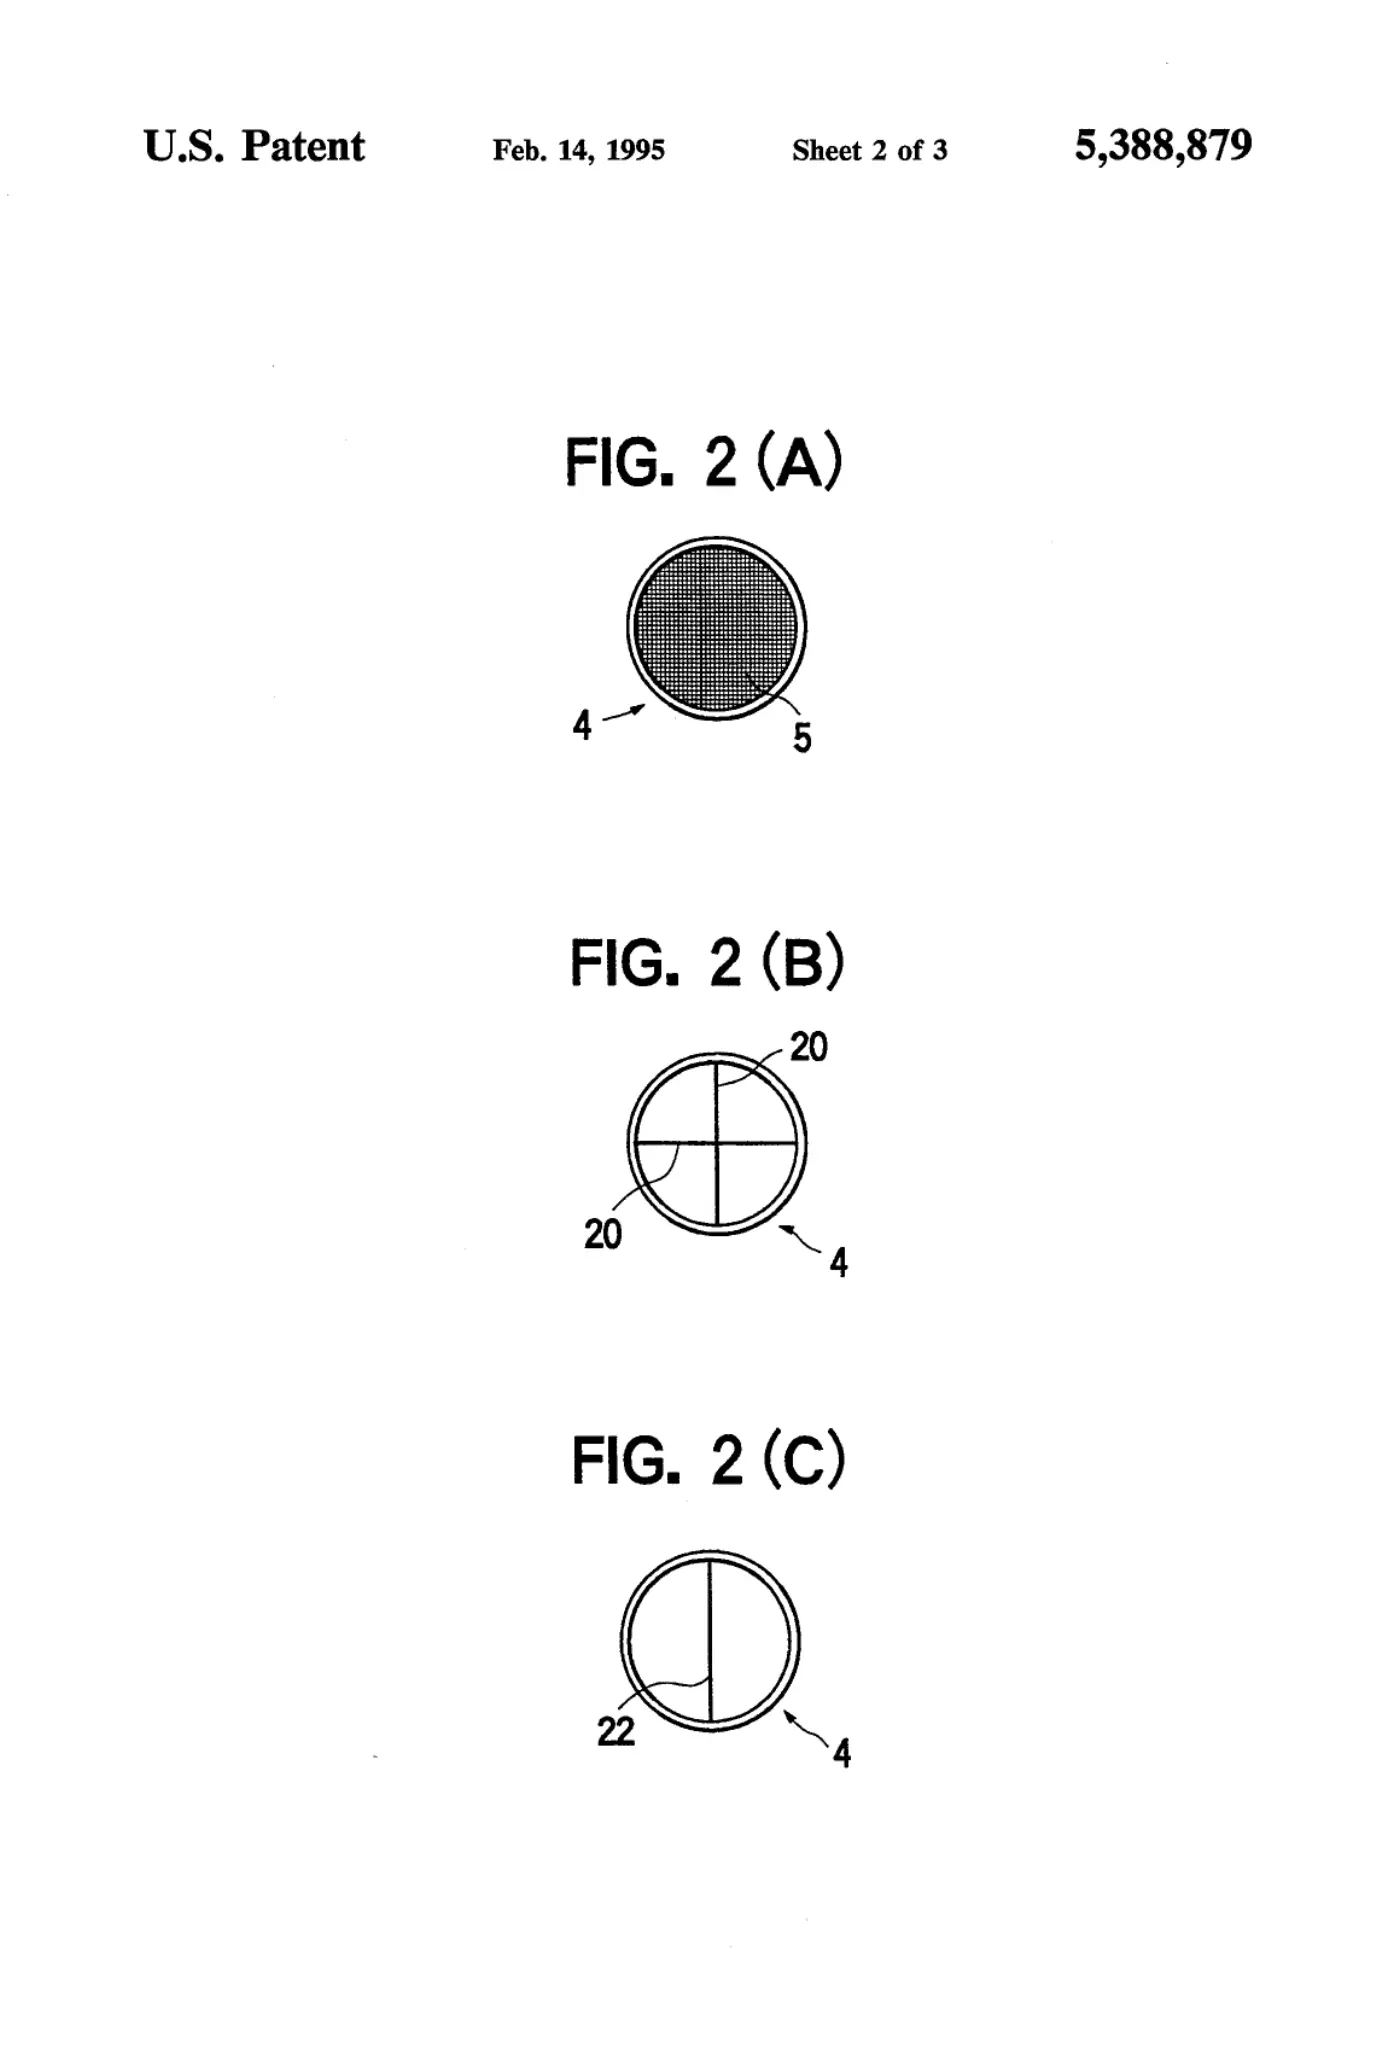
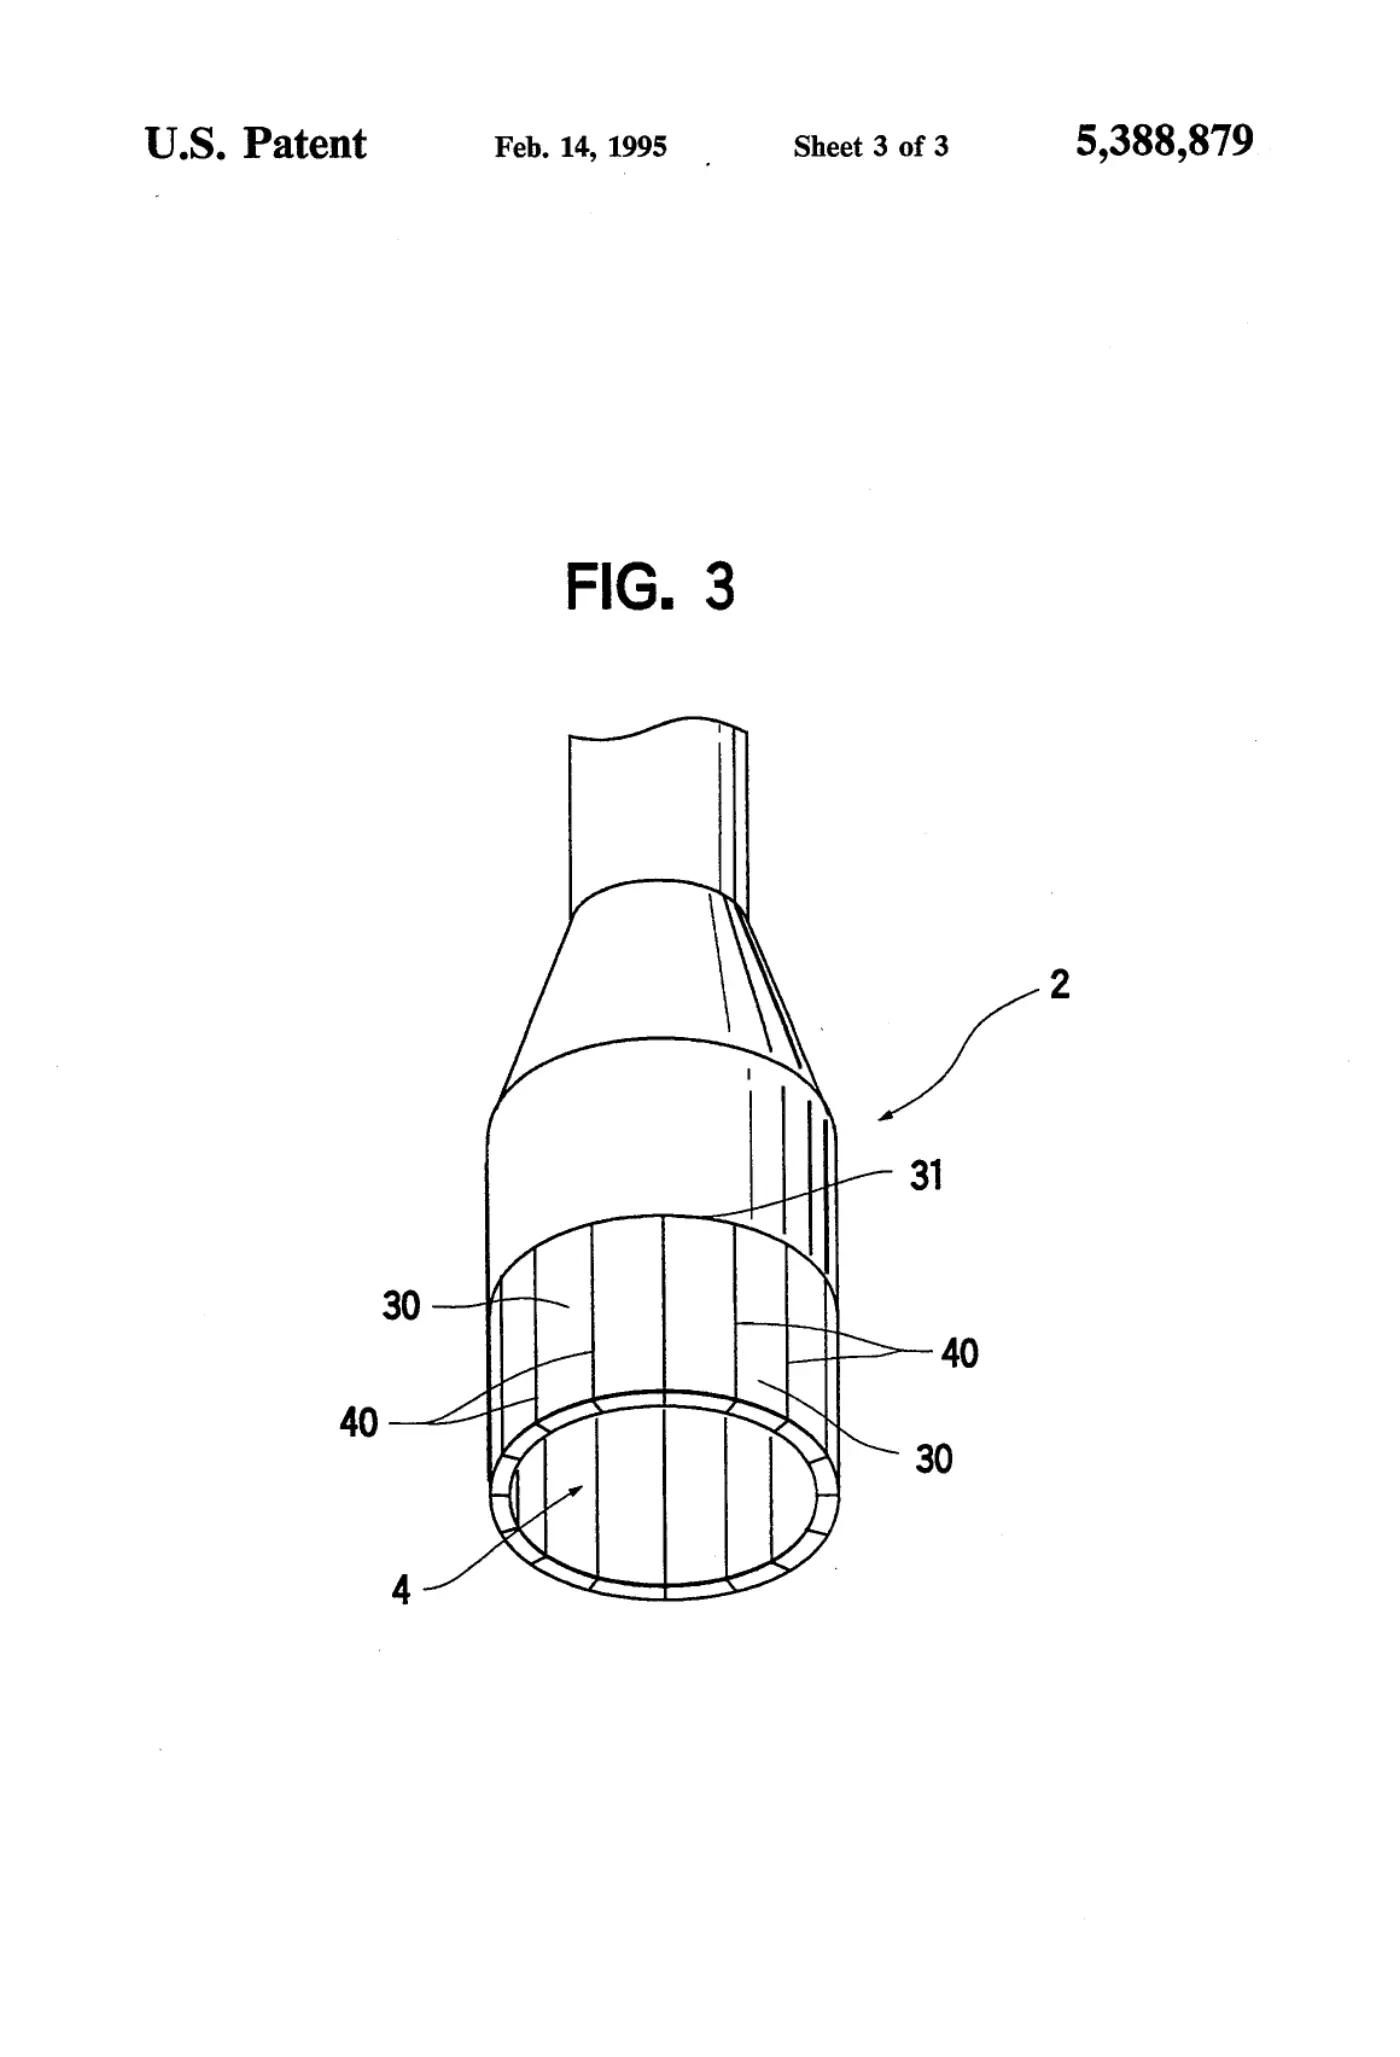
A suction-type metering robot hand comprising (a) a hollow suction pad having a gas-permeable obstacle at an opening of the suction pad; and (b) a main body of the robot hand supporting the suction pad and having a vacuum passage communicating with the suction pad. According to the robot hand of the present invention, the provision of the net on the opening of the suction pad makes it possible to suck fragile articles such as a fried cutlet, roasted bean curd, a piece of bread and the like to a desired place.
Abstract
A suction-type metering robot hand comprising (a) a hollow suction pad having a gas-permeable obstacle at an opening of the suction pad; and (b) a main body of the robot hand supporting the suction pad and having a vacuum passage communicating with the suction pad. According to the robot hand of the present invention, the provision of the net on the opening of the suction pad makes it possible to suck fragile articles such as a fried cutlet, roasted bean curd, a piece of bread and the like to a desired place.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
Publication information
Citation
OpenTechnical Publication OT-2026-000003318, “Suction type robot hand,” published September 15, 2026 at 20:08:52 UTC, https://opentechnical.org/p/OT-2026-000003318.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.