OT-2026-000003329
Method and apparatus for electro-optically determining the dimension, location and attitude of objects
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003329
- Classification
- Sensors, Controls & Machine Vision › Position and Presence Sensing
- Assignee
- SENSOR ADAPTIVE MACH
- Original source
- US-5362970-A, the United States Patent and Trademark Office, 8 November 1994
- Document SHA-256
- 12342bf0a456f21ba6016a170b1bb702141b73842b49dc54a3e7b122f9333d09
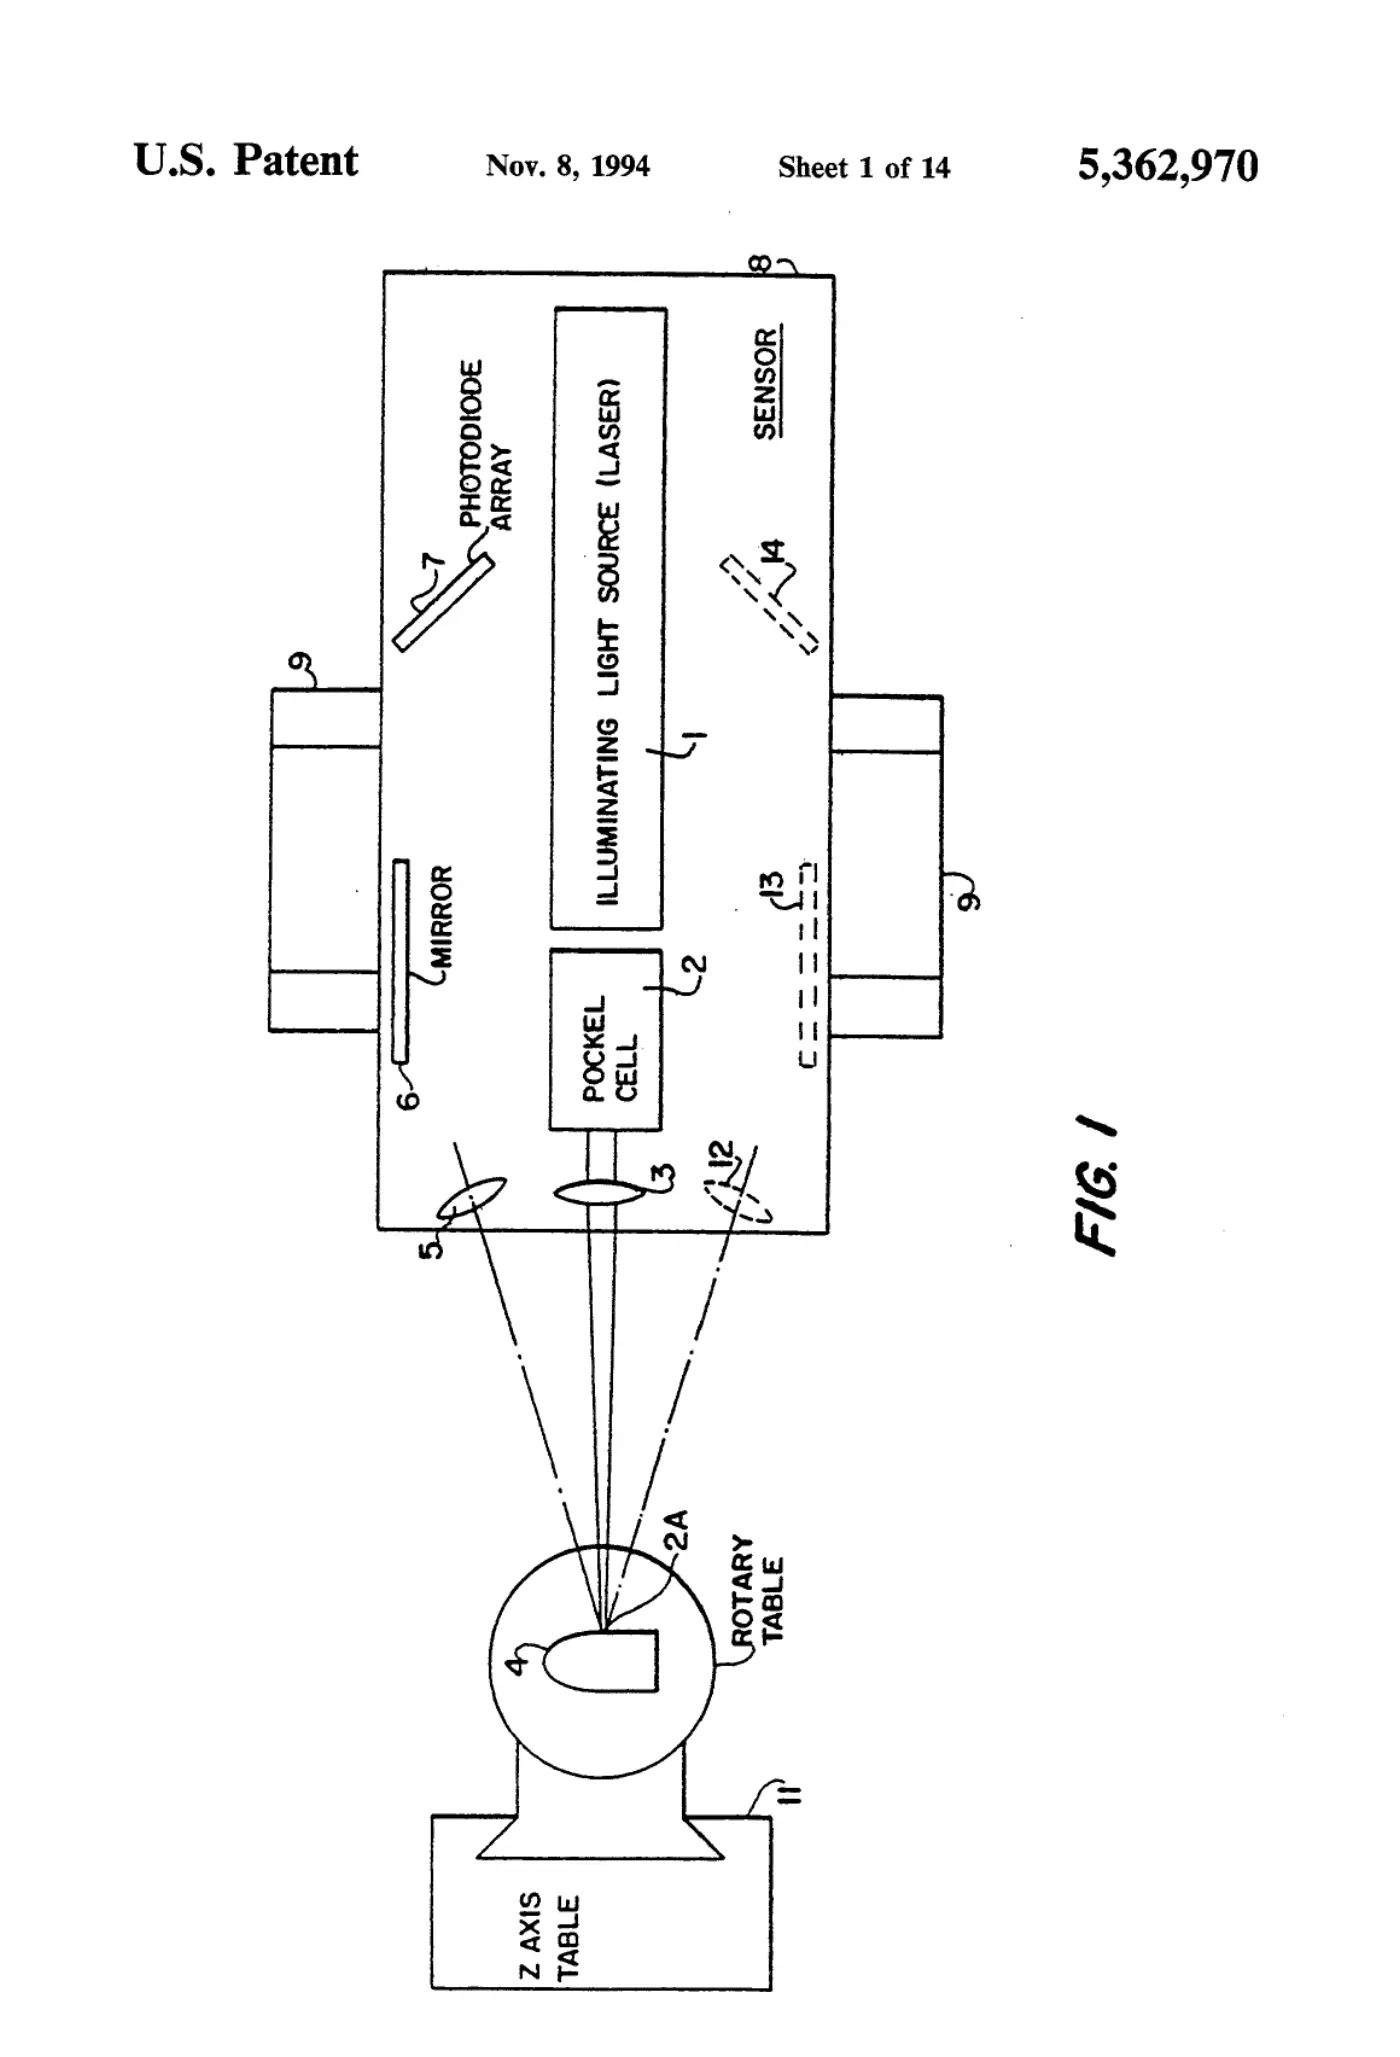
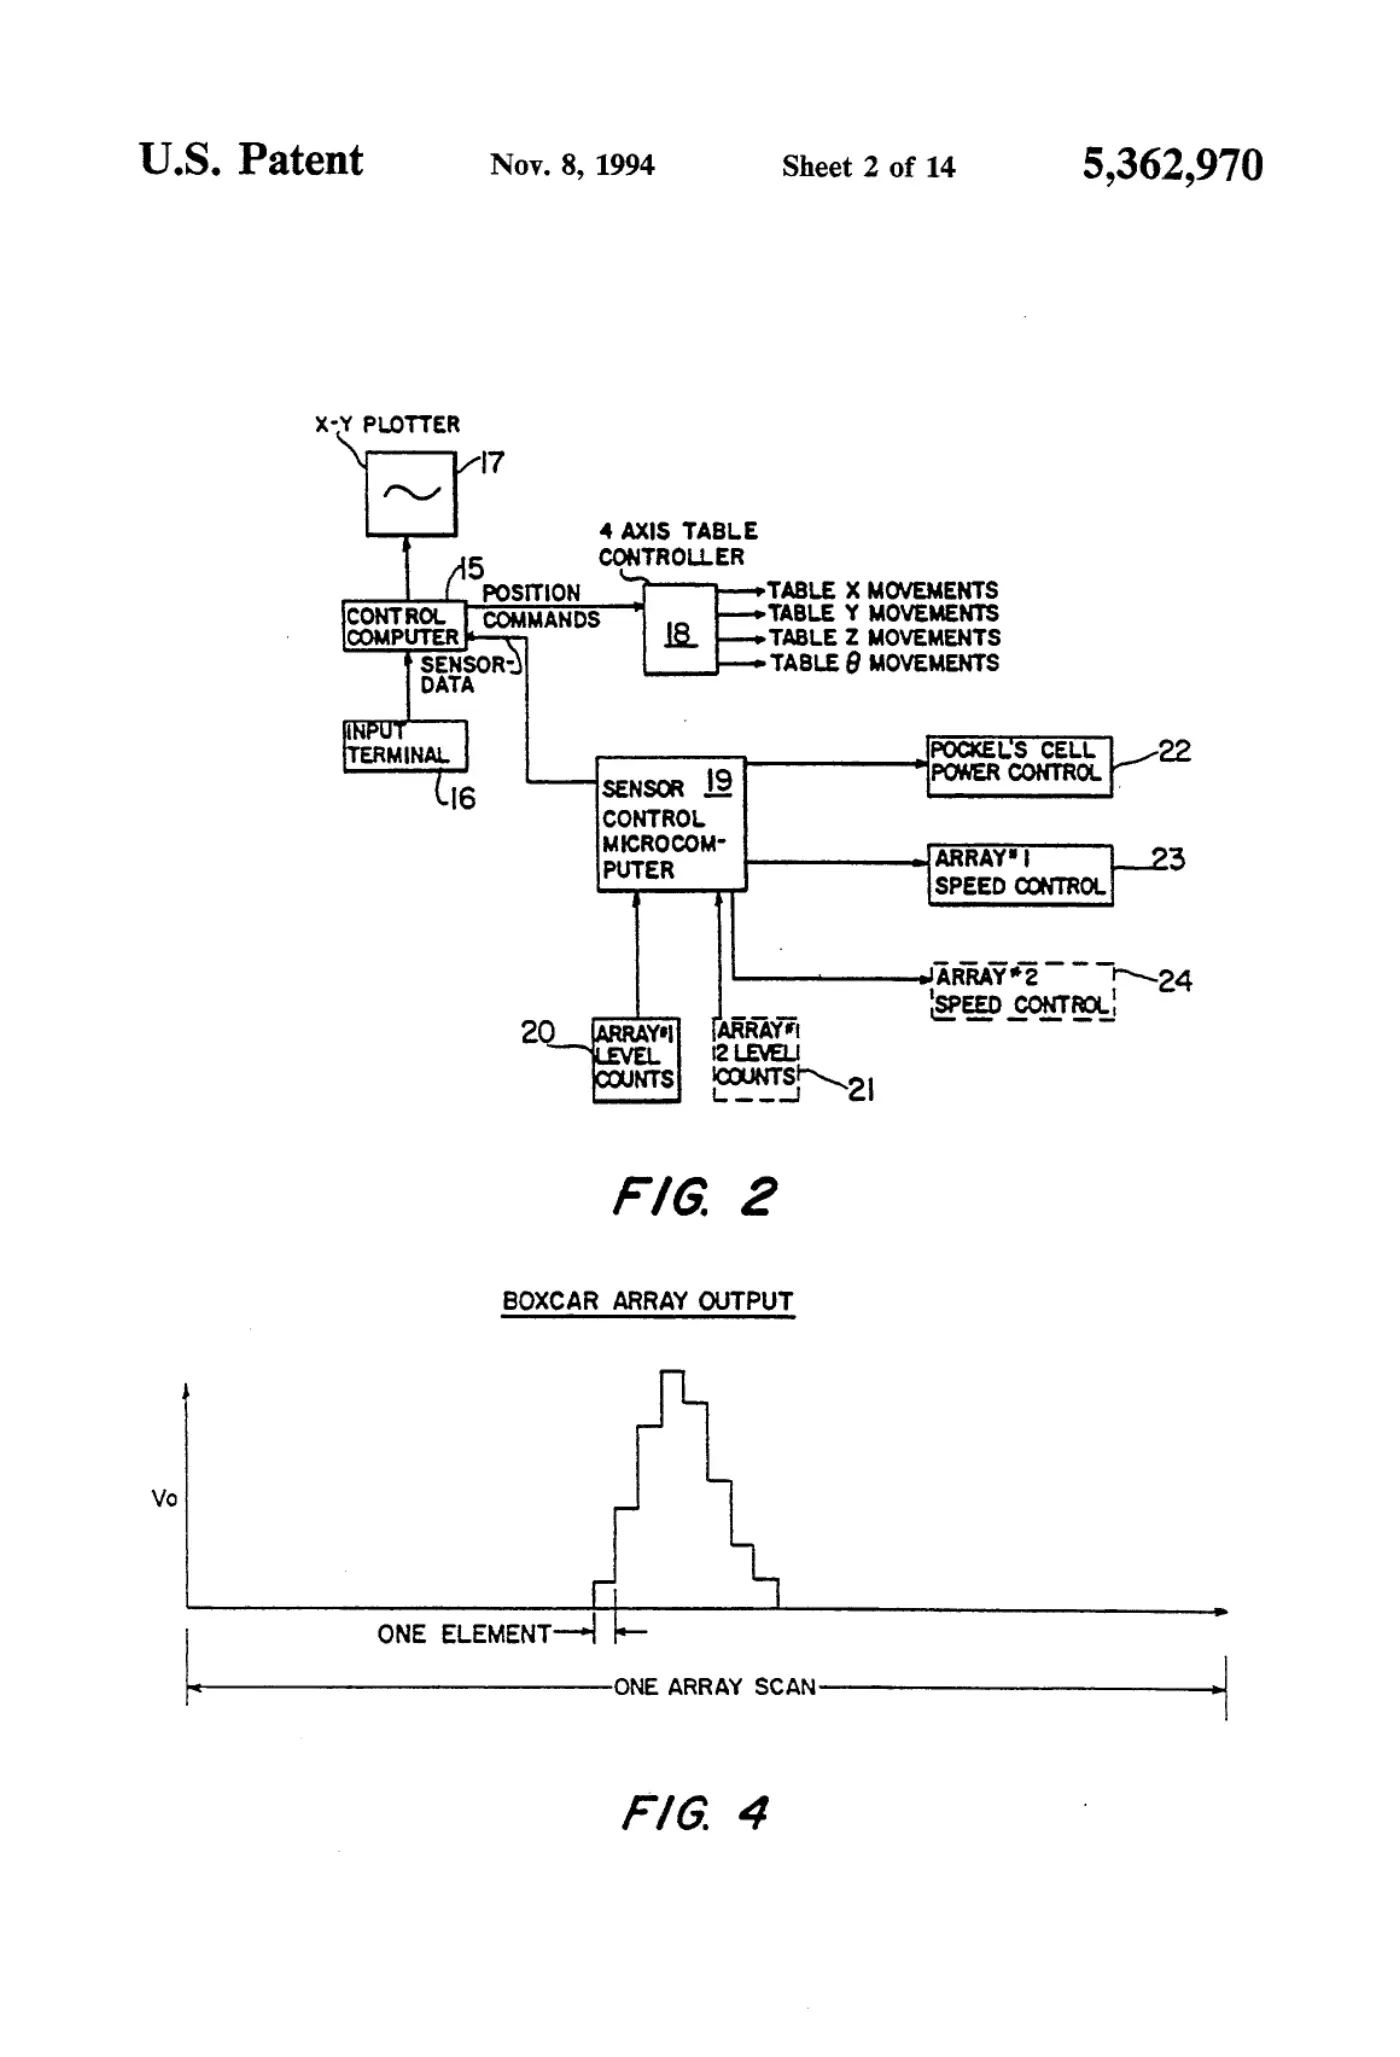
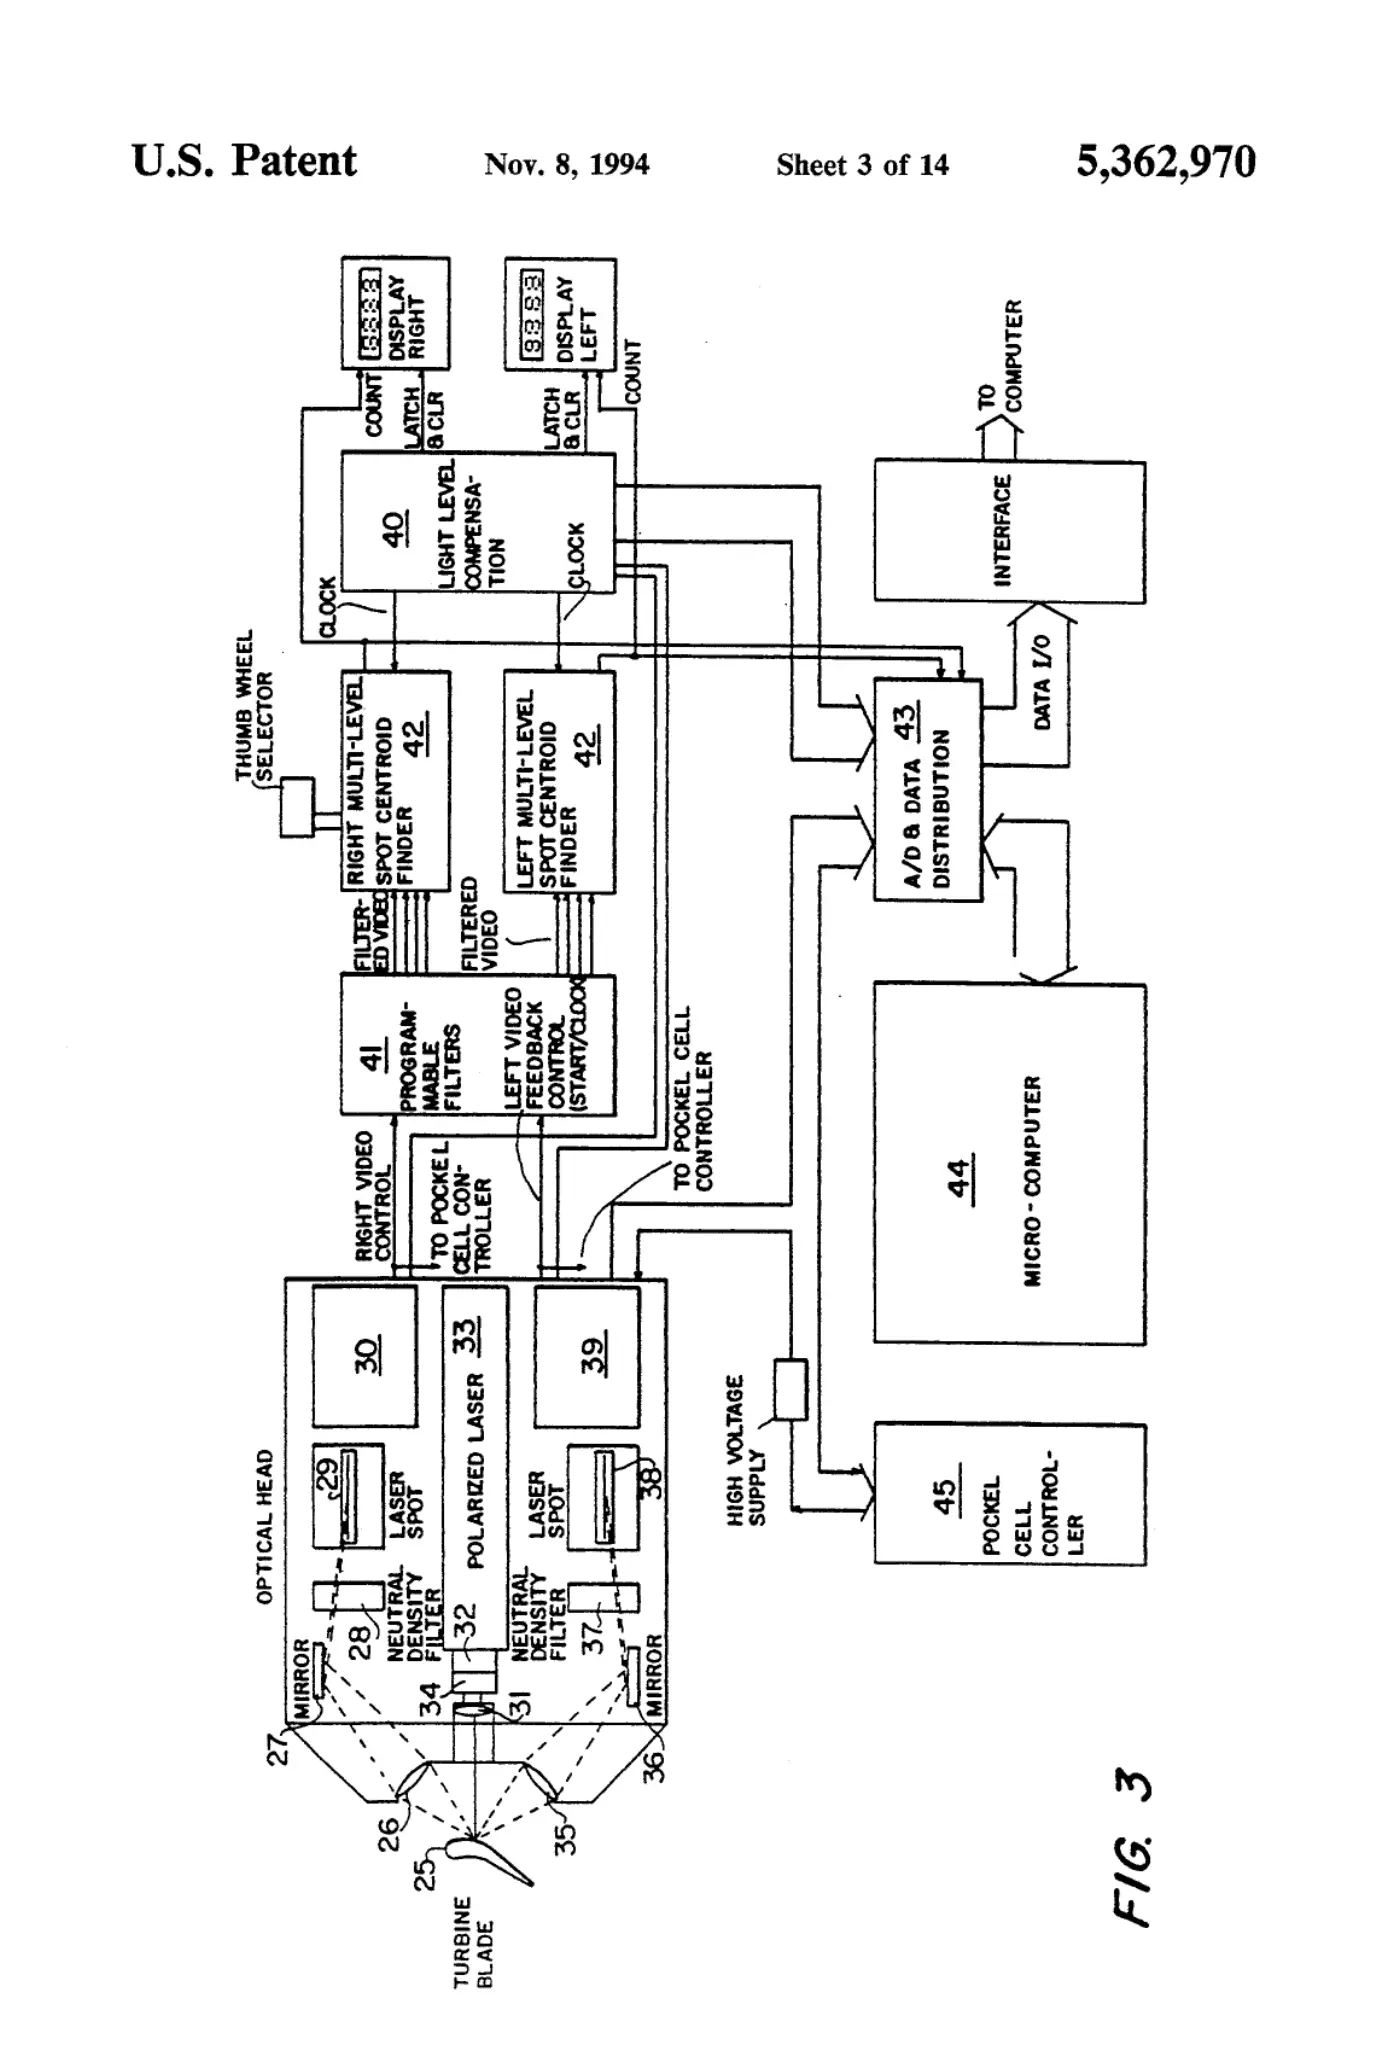
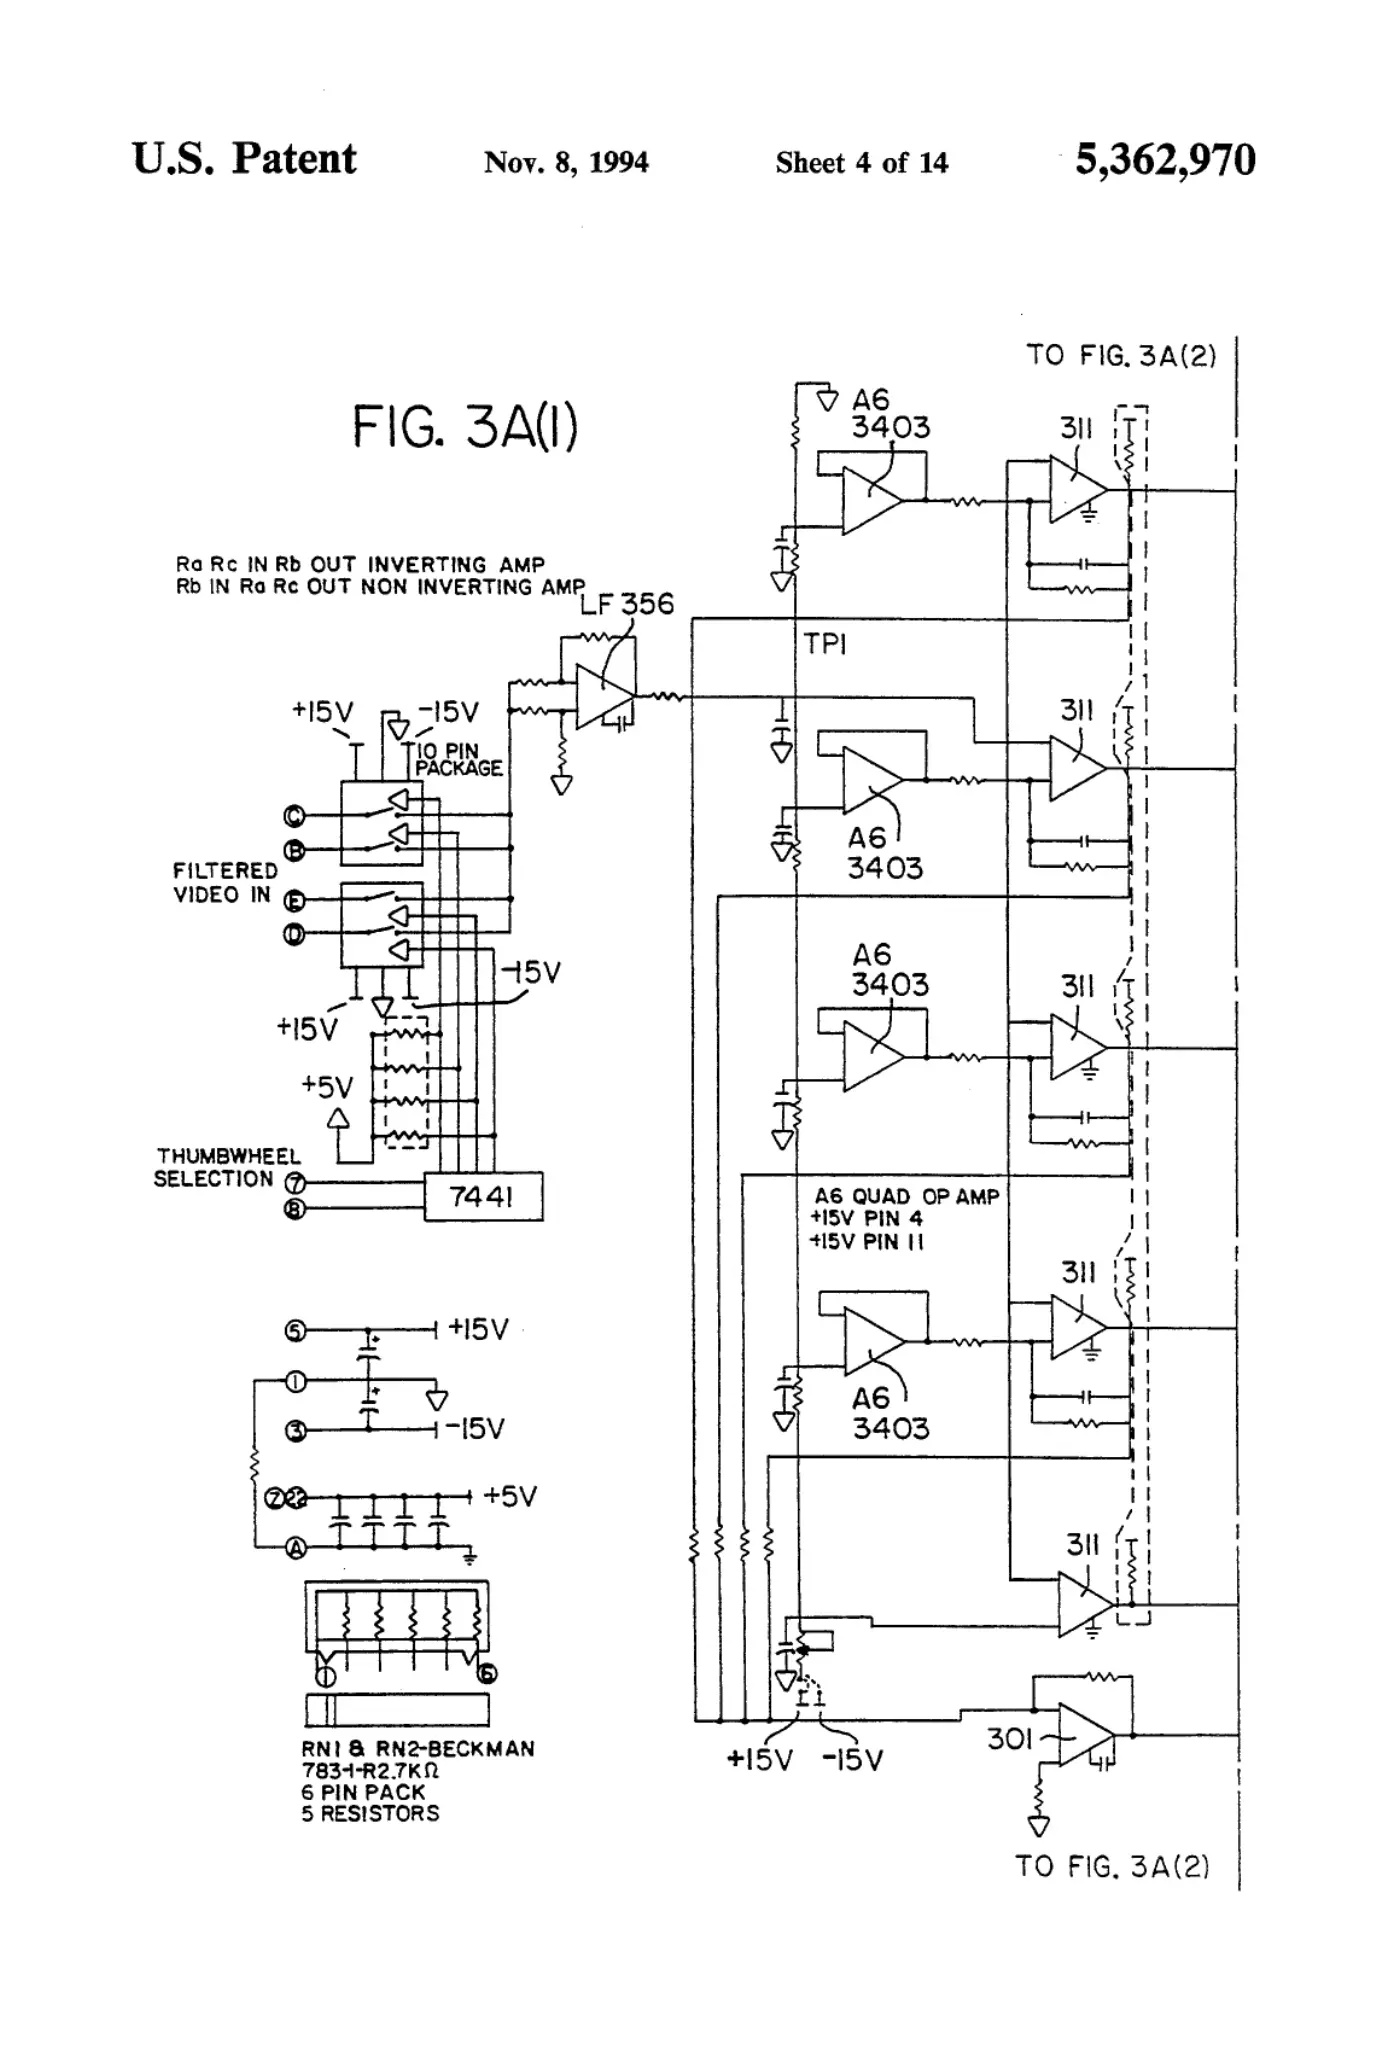
This invention discloses method and apparatus for optically determining the dimension of part surfaces. Particular embodiments describe optical triangulation based coordinate measurement machines capable of accurate measurement of complex surfaces, such as gear teeth and turbine blades. Other embodiments provide highly useful sensors for robot guidance and related purposes. Up to 5 axis sensing capability is provided on surfaces of widely varying form.
Abstract
This invention discloses method and apparatus for optically determining the dimension of part surfaces. Particular embodiments describe optical triangulation based coordinate measurement machines capable of accurate measurement of complex surfaces, such as gear teeth and turbine blades. Other embodiments provide highly useful sensors for robot guidance and related purposes. Up to 5 axis sensing capability is provided on surfaces of widely varying form.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
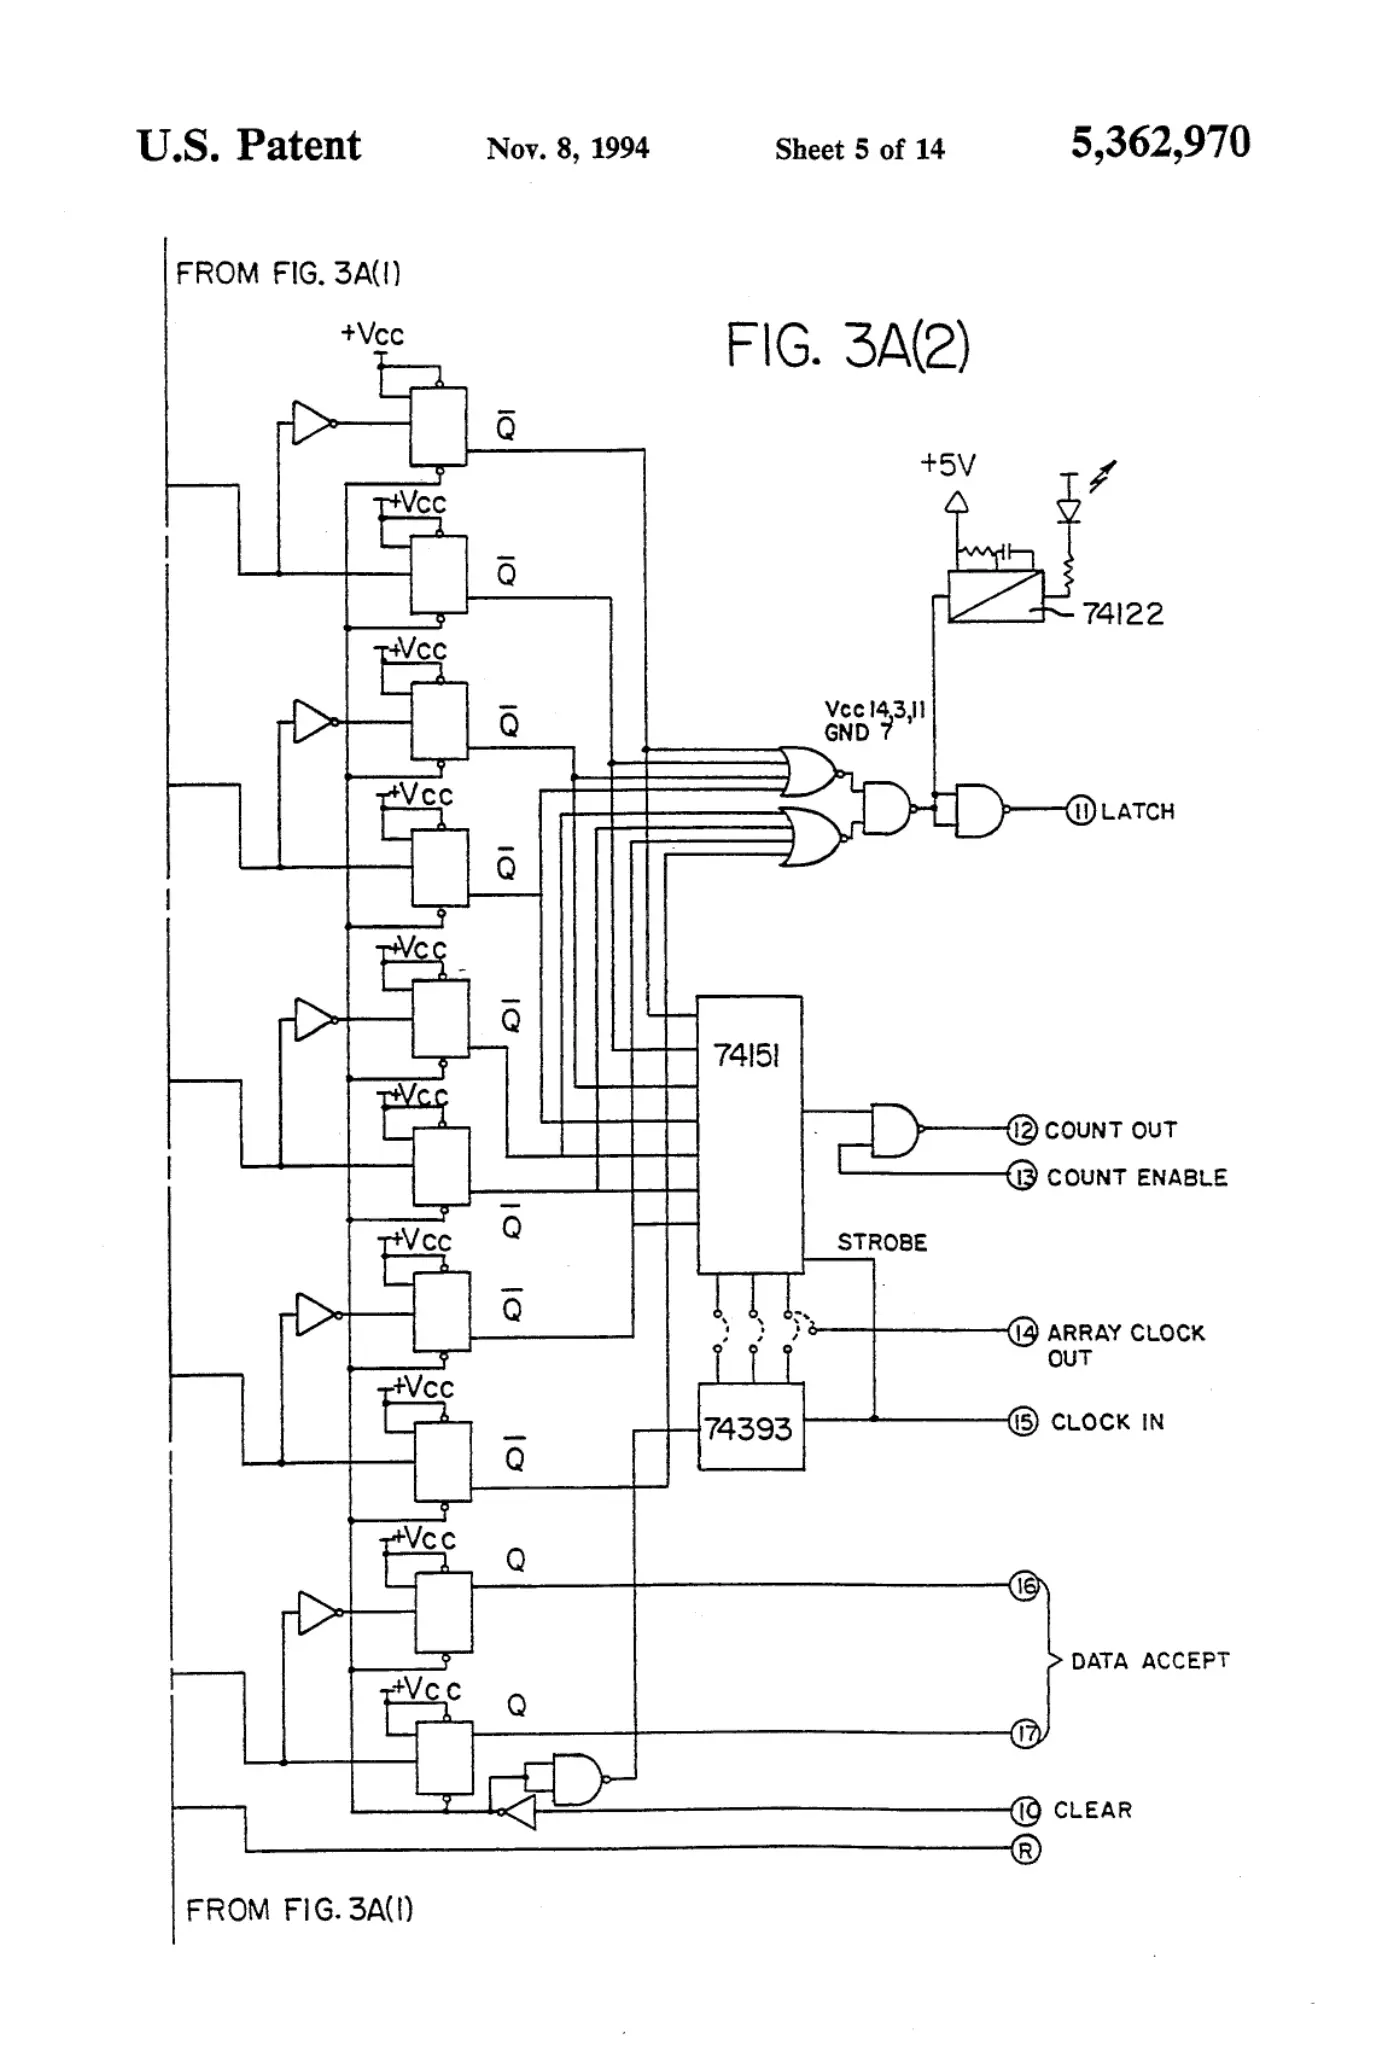
[0005]Sheet 5.
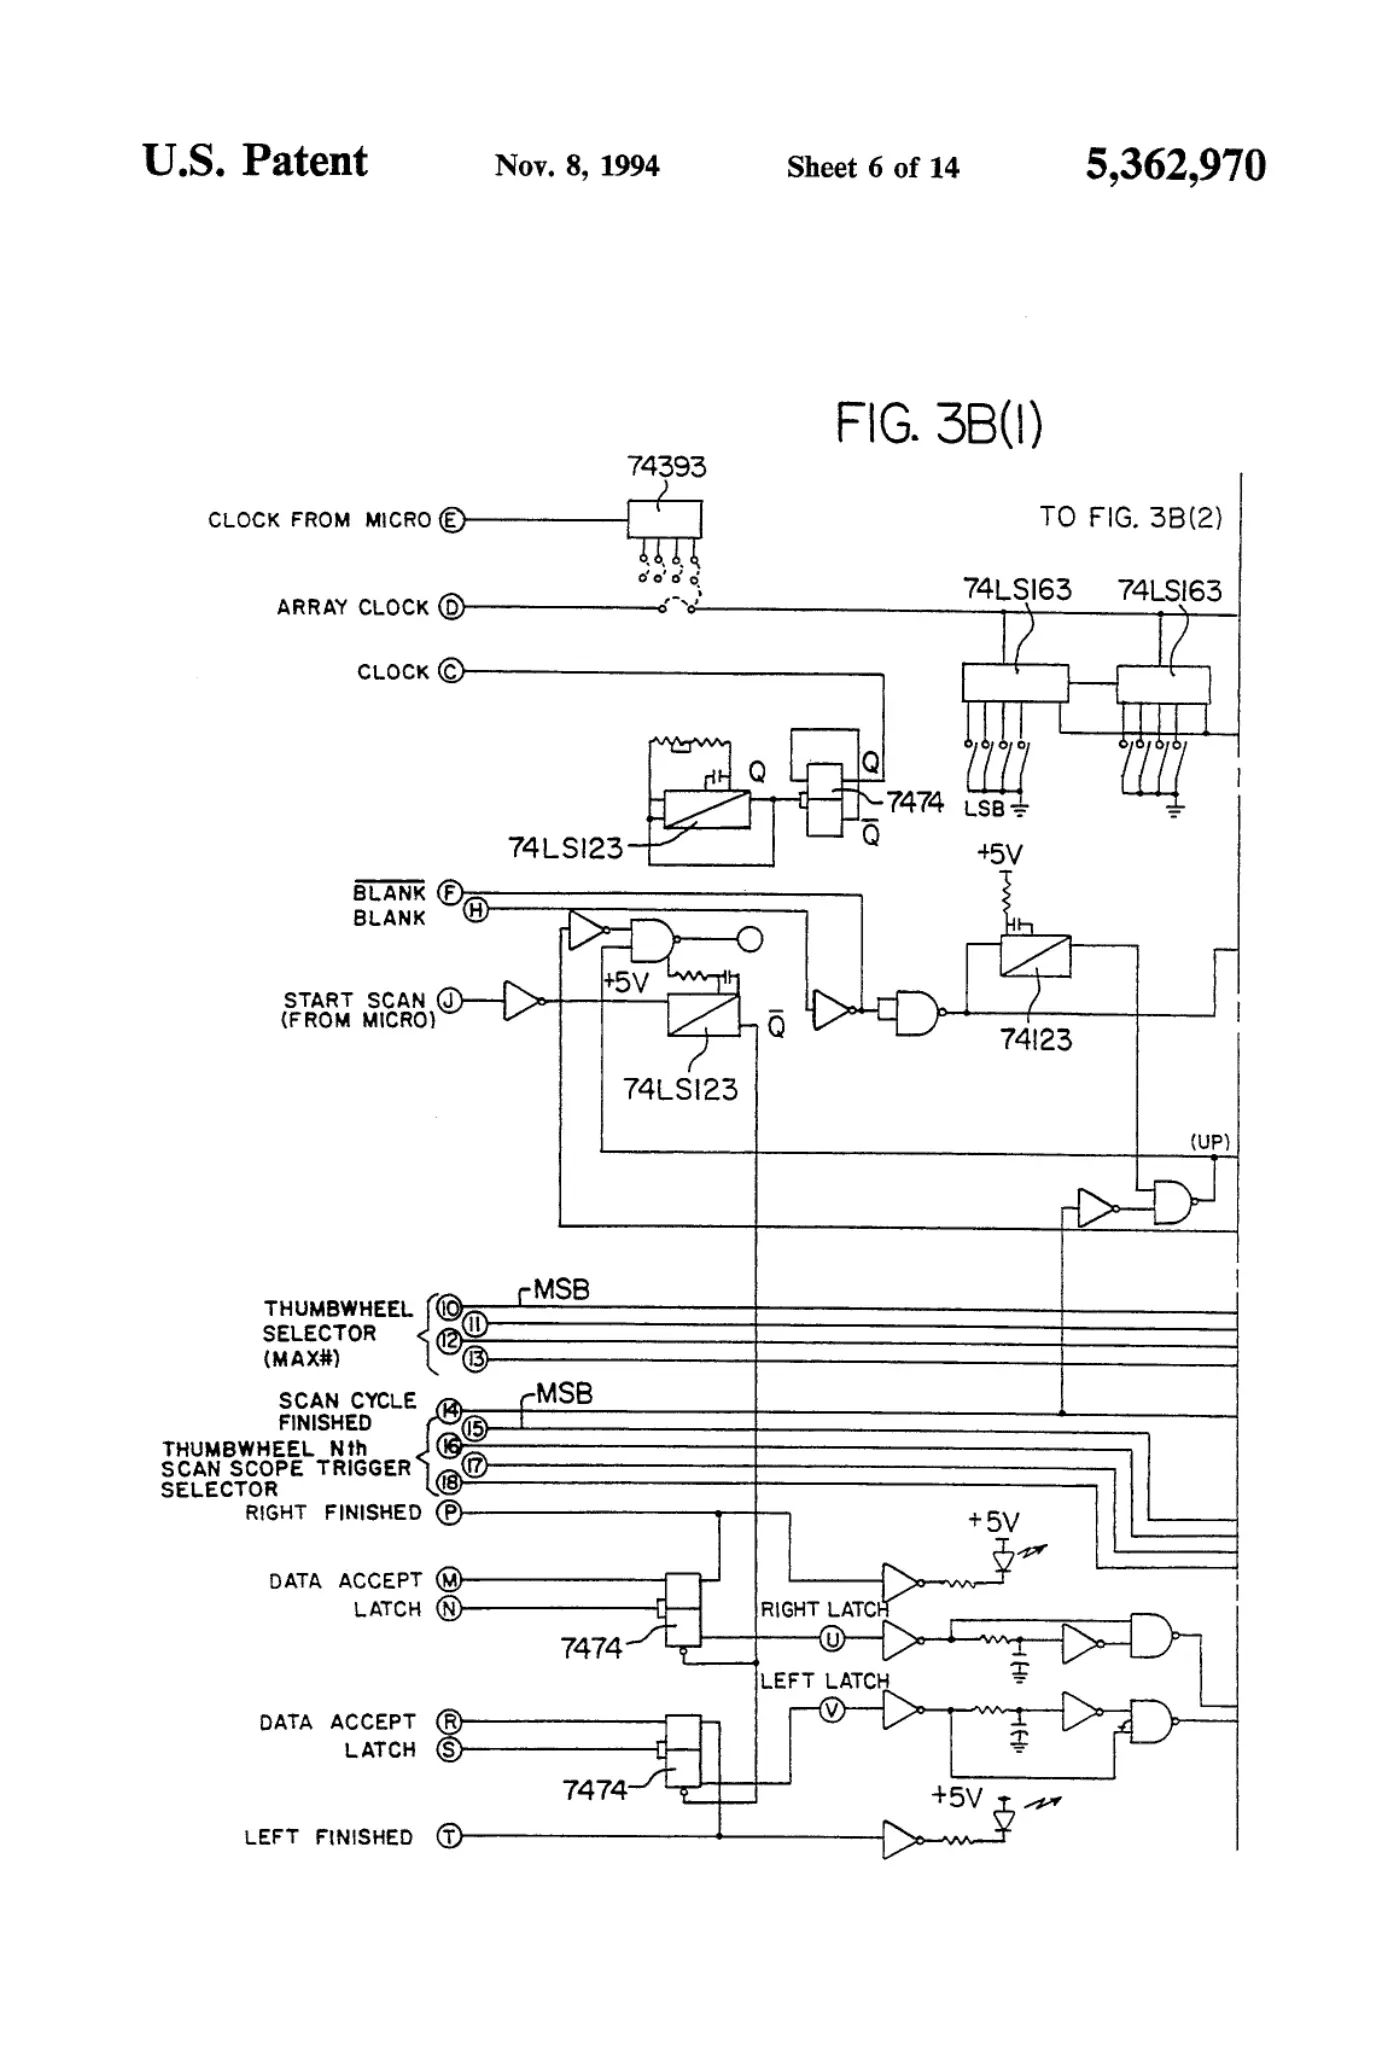
[0006]Sheet 6.
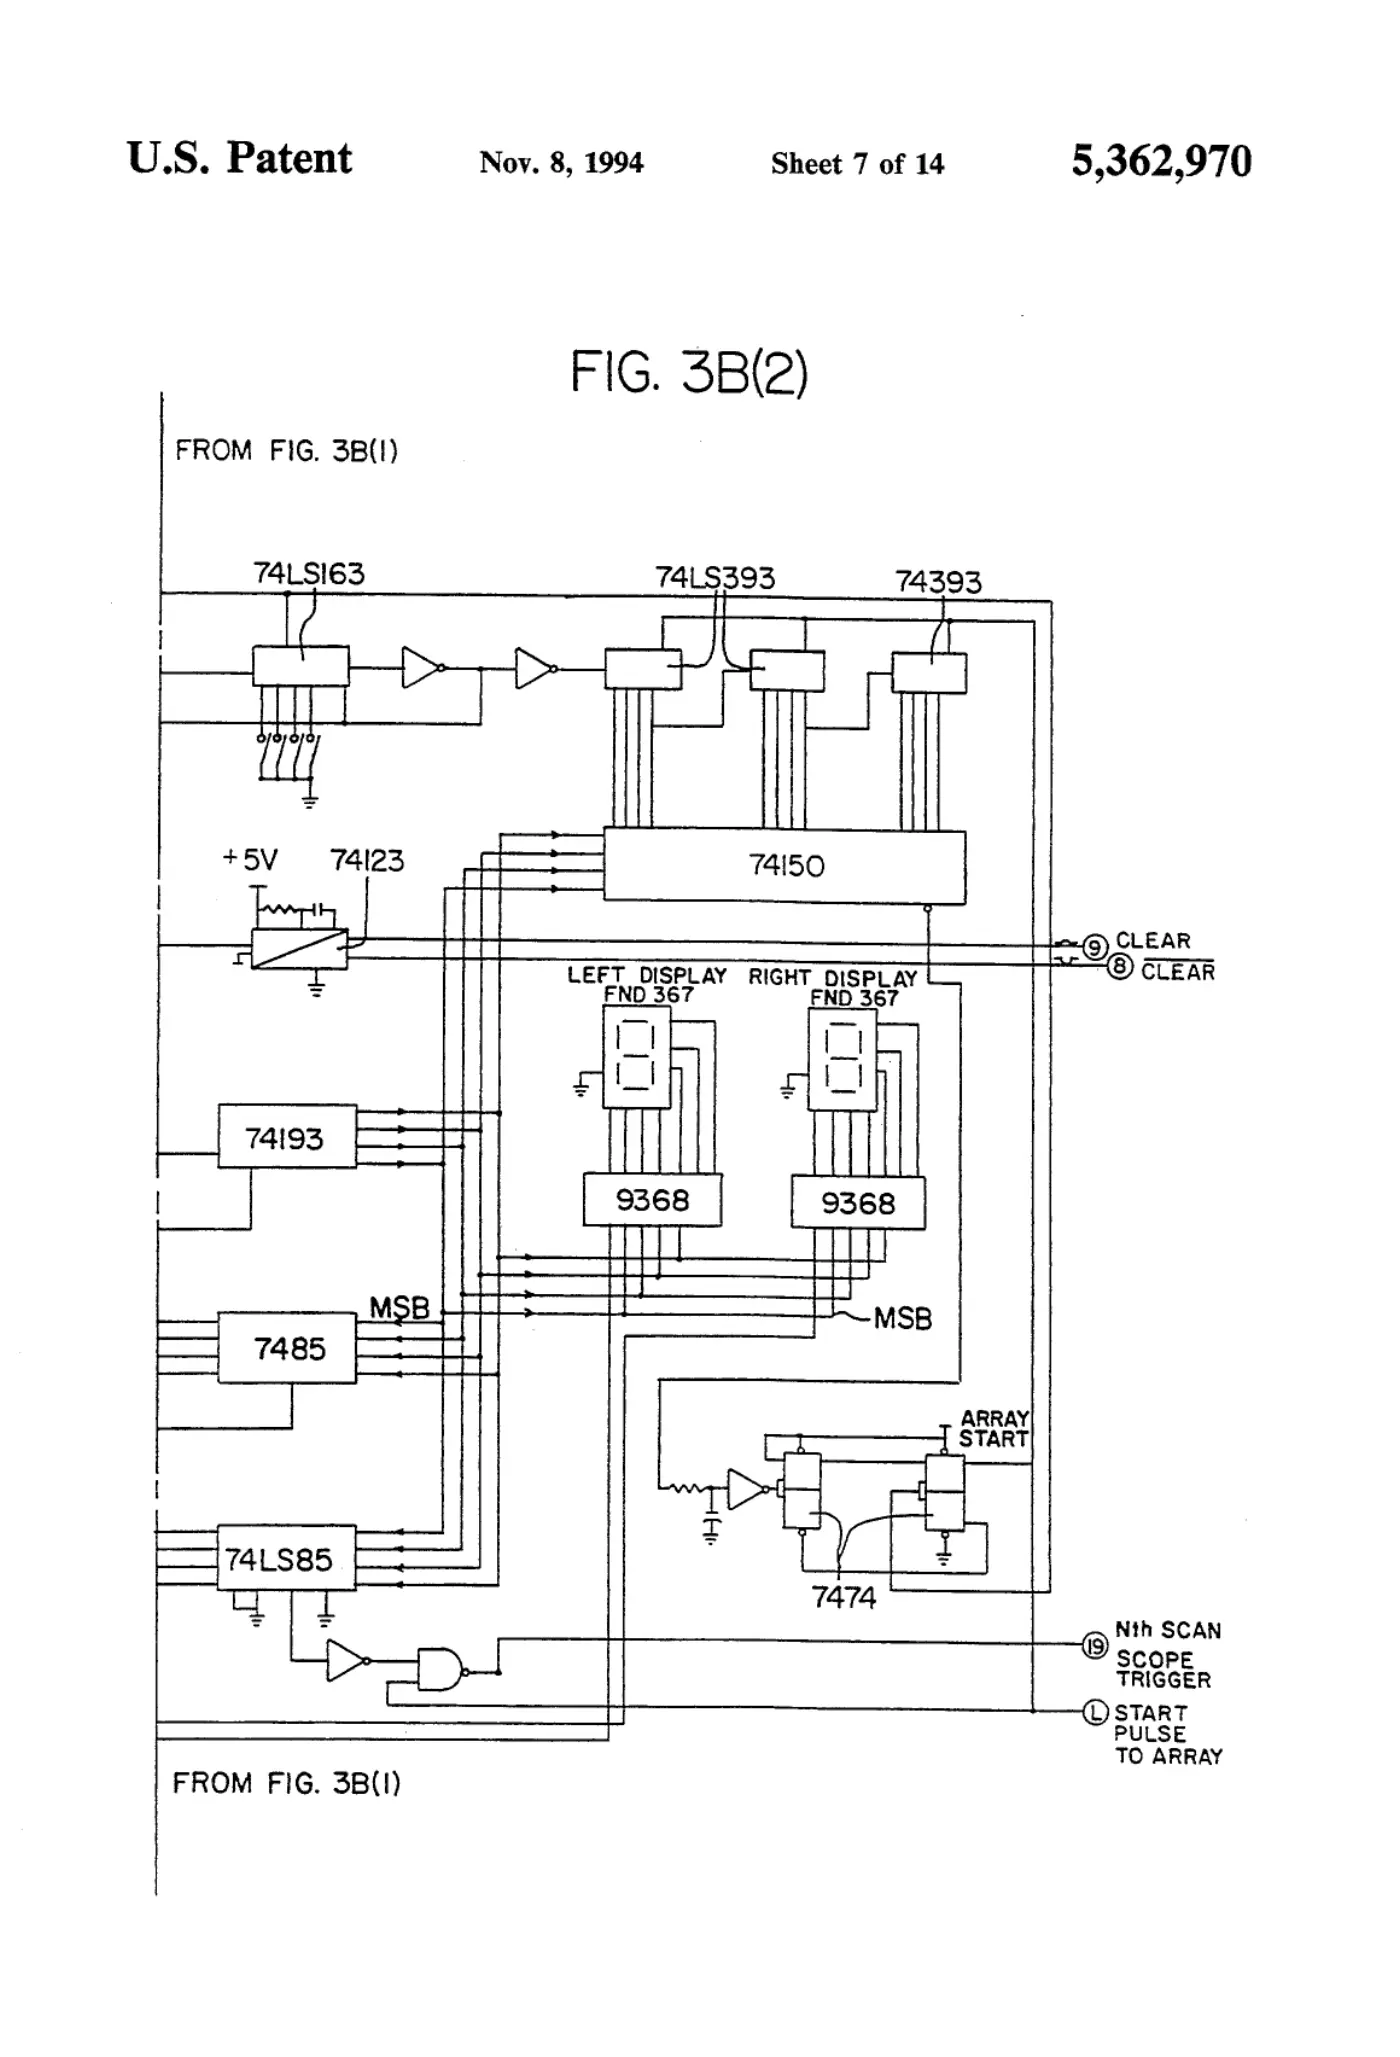
[0007]Sheet 7.
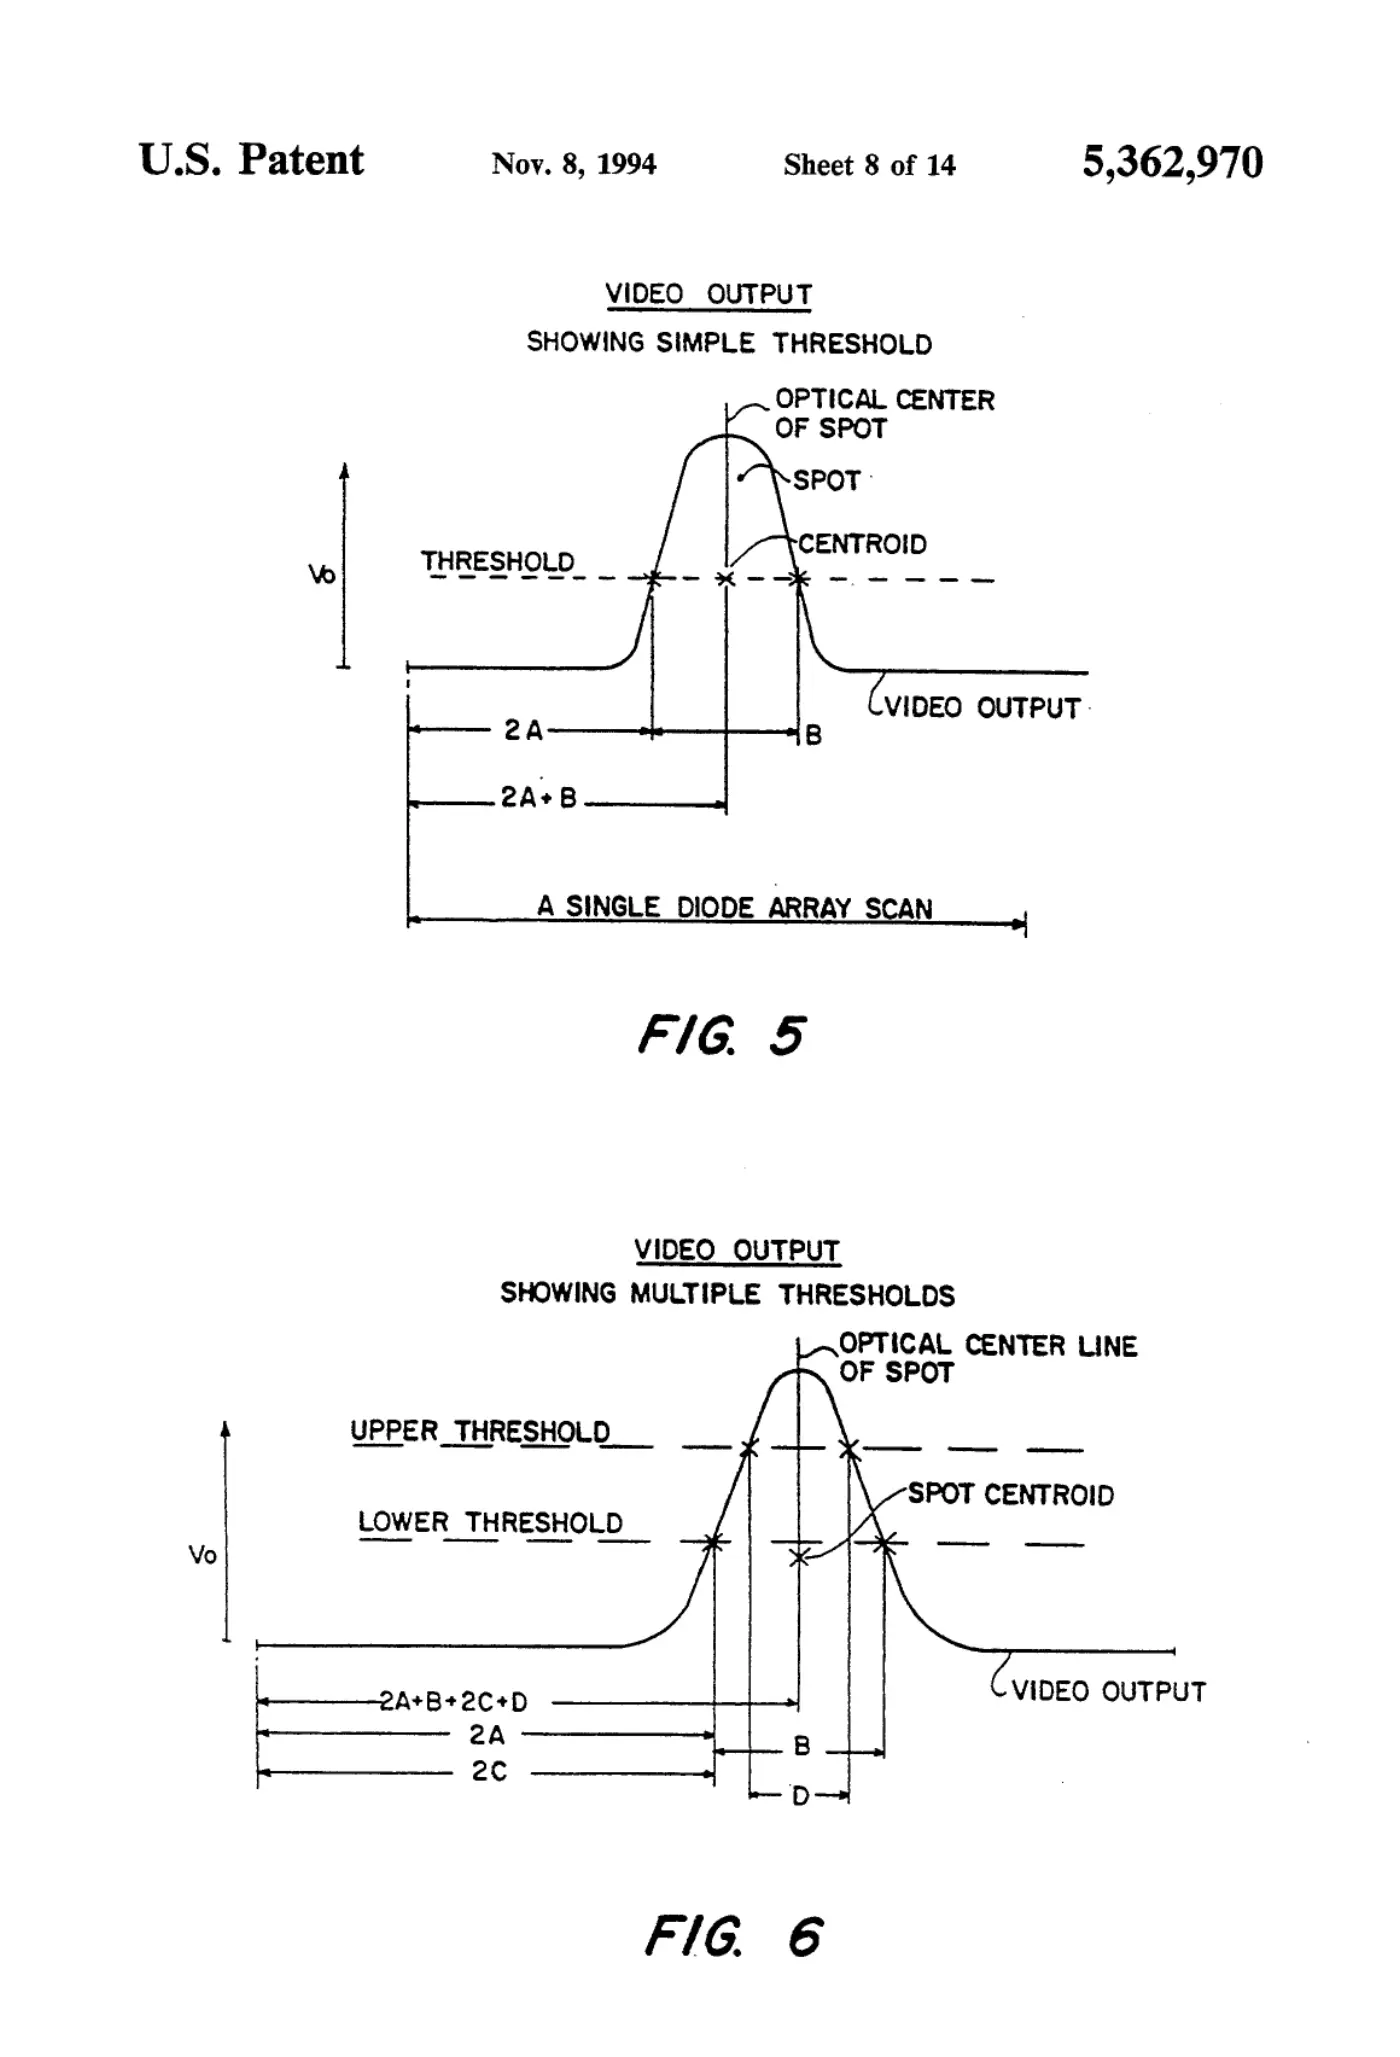
[0008]Sheet 8.
[0009]Sheet 9.
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003329, “Method and apparatus for electro-optically determining the dimension, location and attitude of objects,” published September 15, 2026 at 20:10:35 UTC, https://opentechnical.org/p/OT-2026-000003329.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.