OT-2026-000003334
Walking robot
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003334
- Classification
- Robotics & Automation › End Effectors
- Assignee
- YANAGISAWA KEN
- Original source
- US-5351626-A, the United States Patent and Trademark Office, 4 October 1994
- Document SHA-256
- 41c0ebc615b098b0da87bb0e4e781bb70eebd50f70292a9433a8167744b7597b
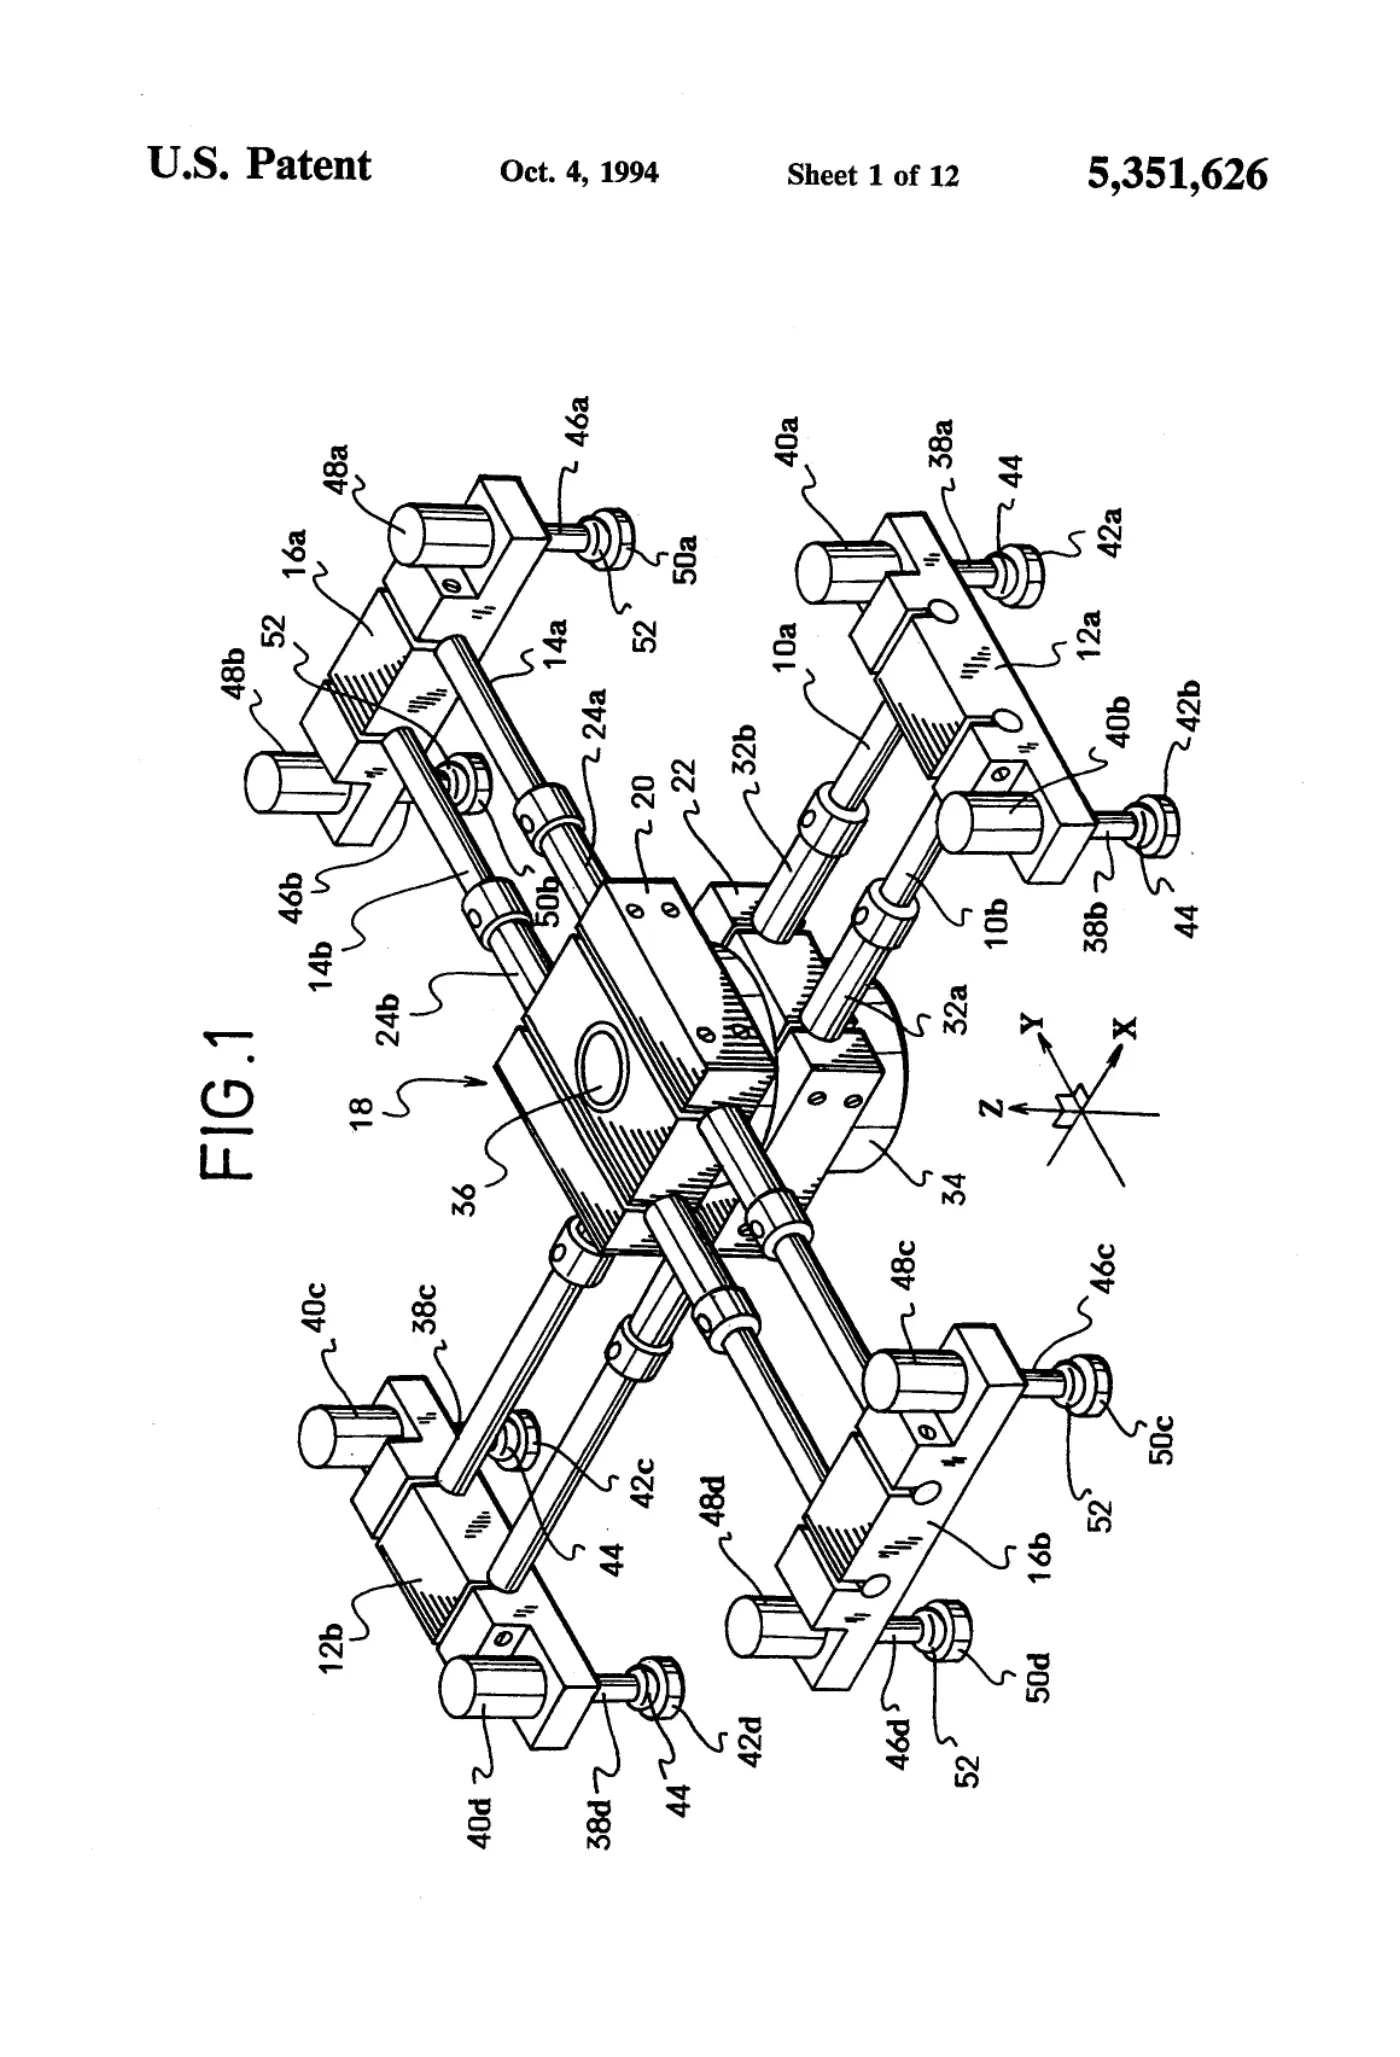
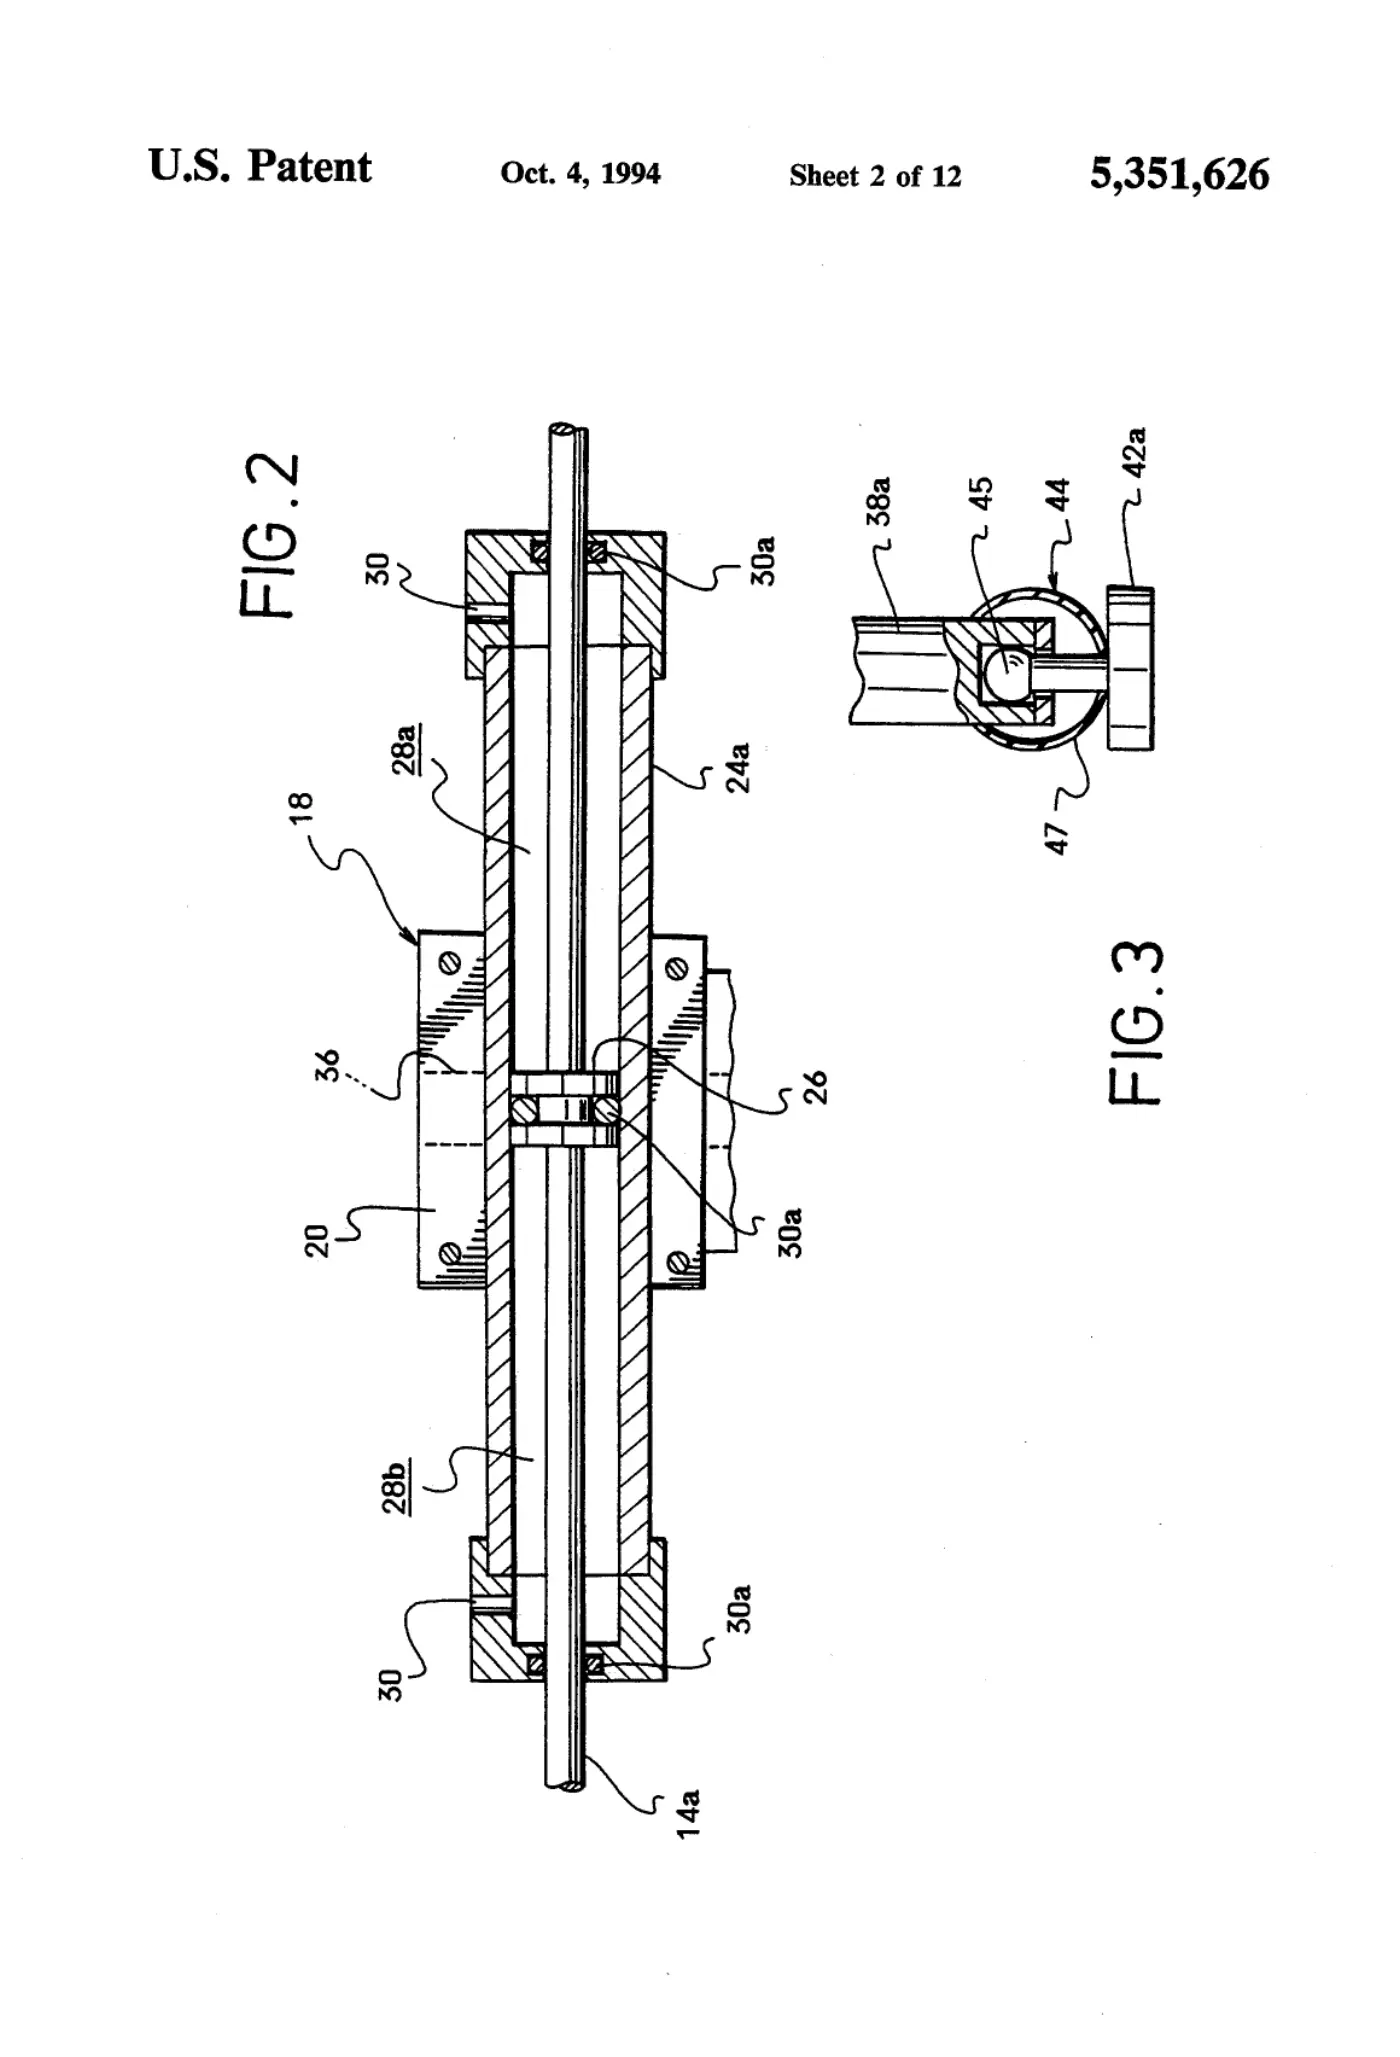
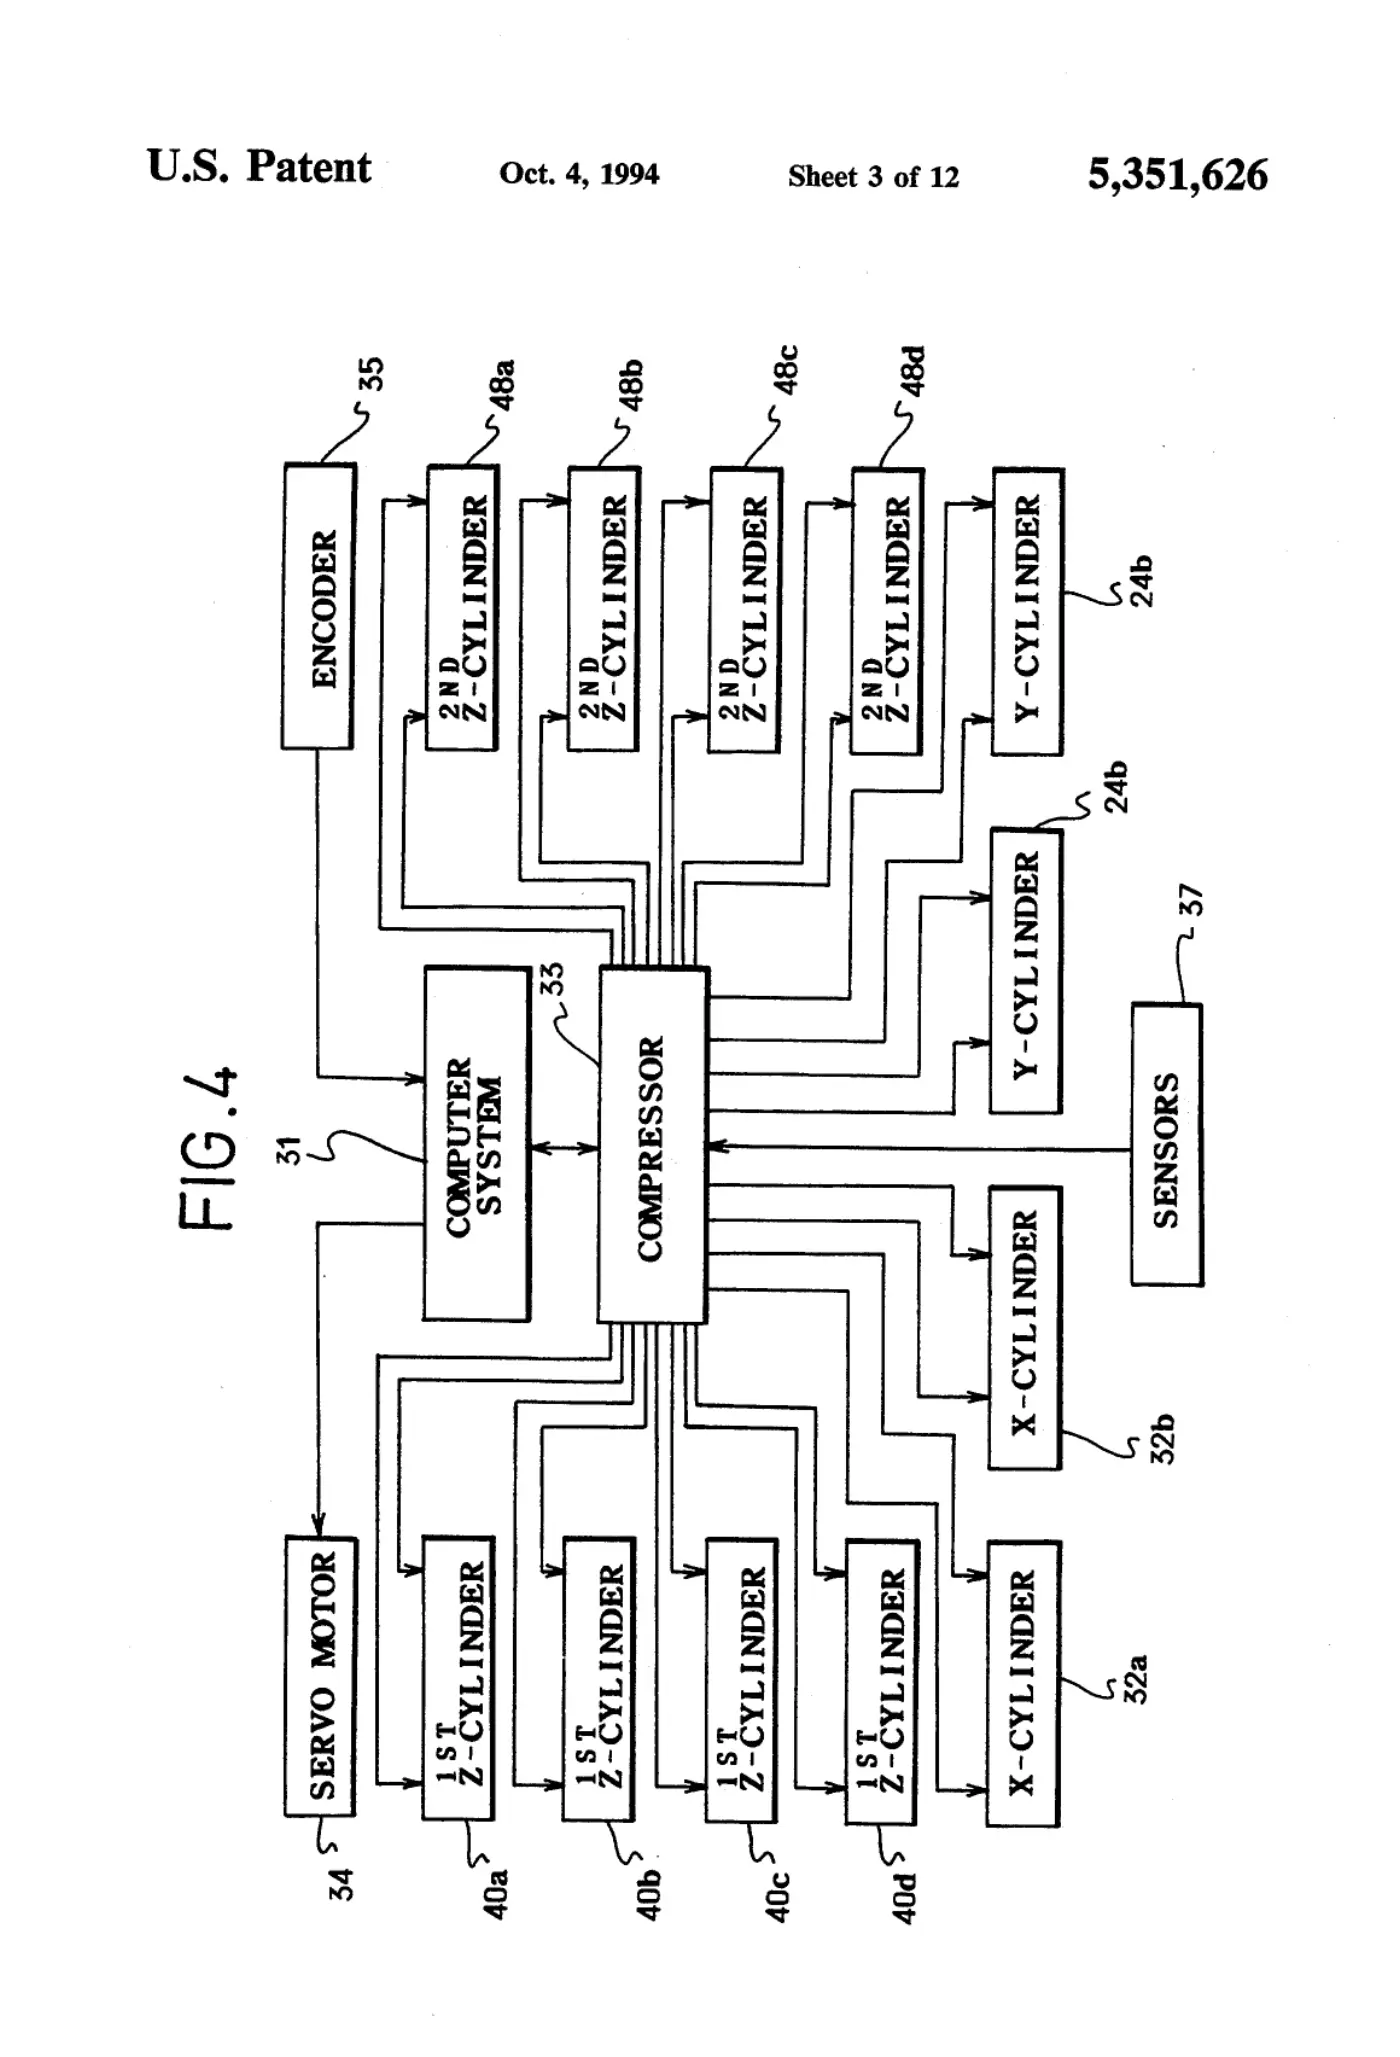
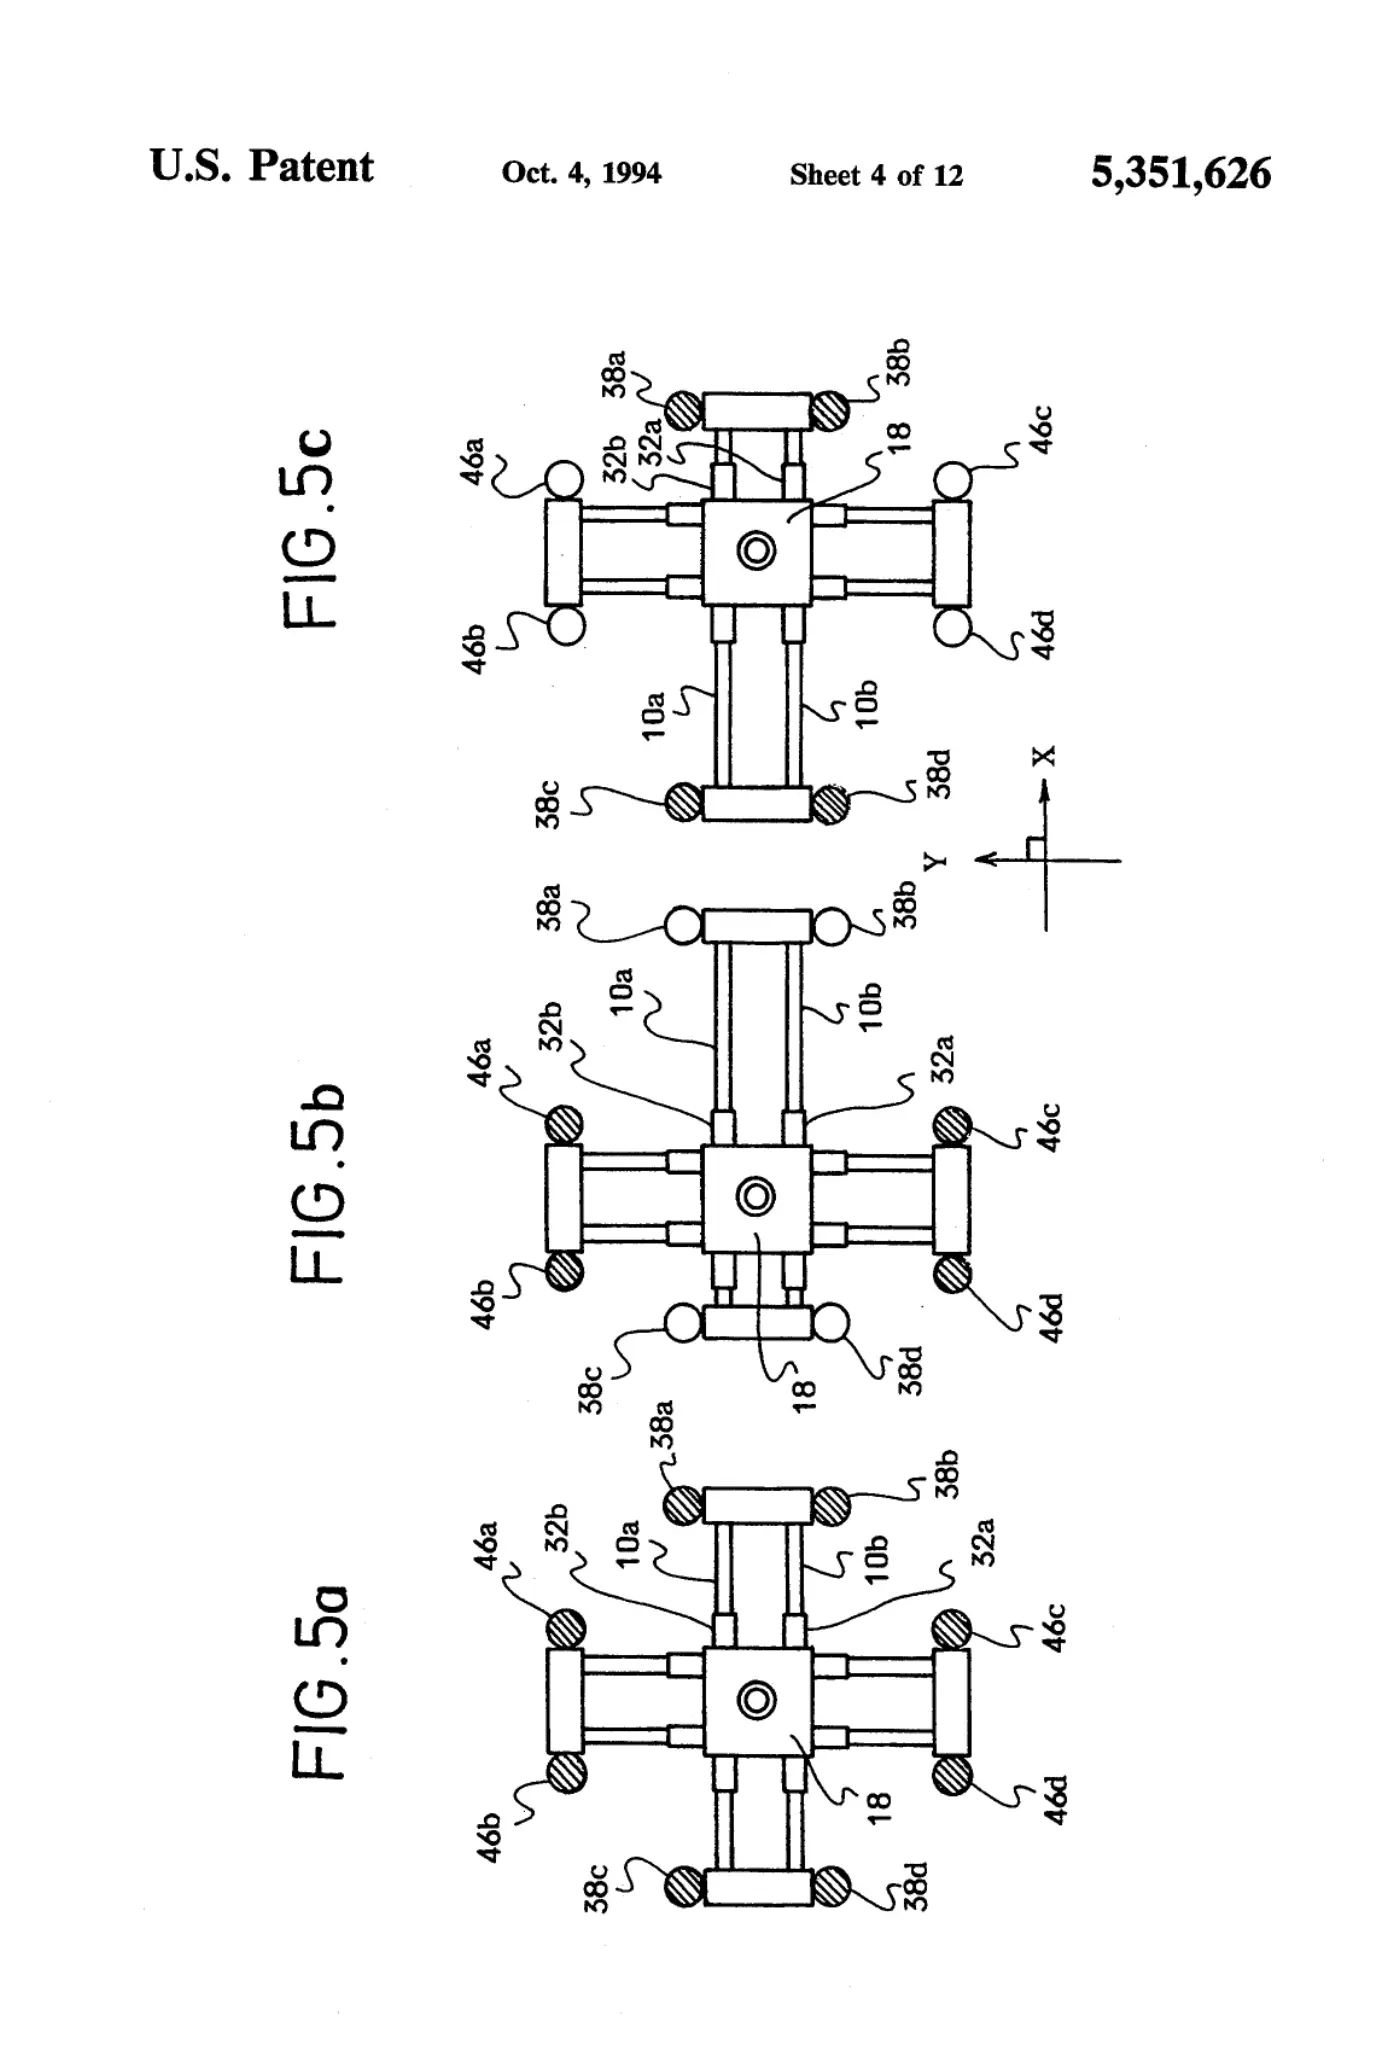
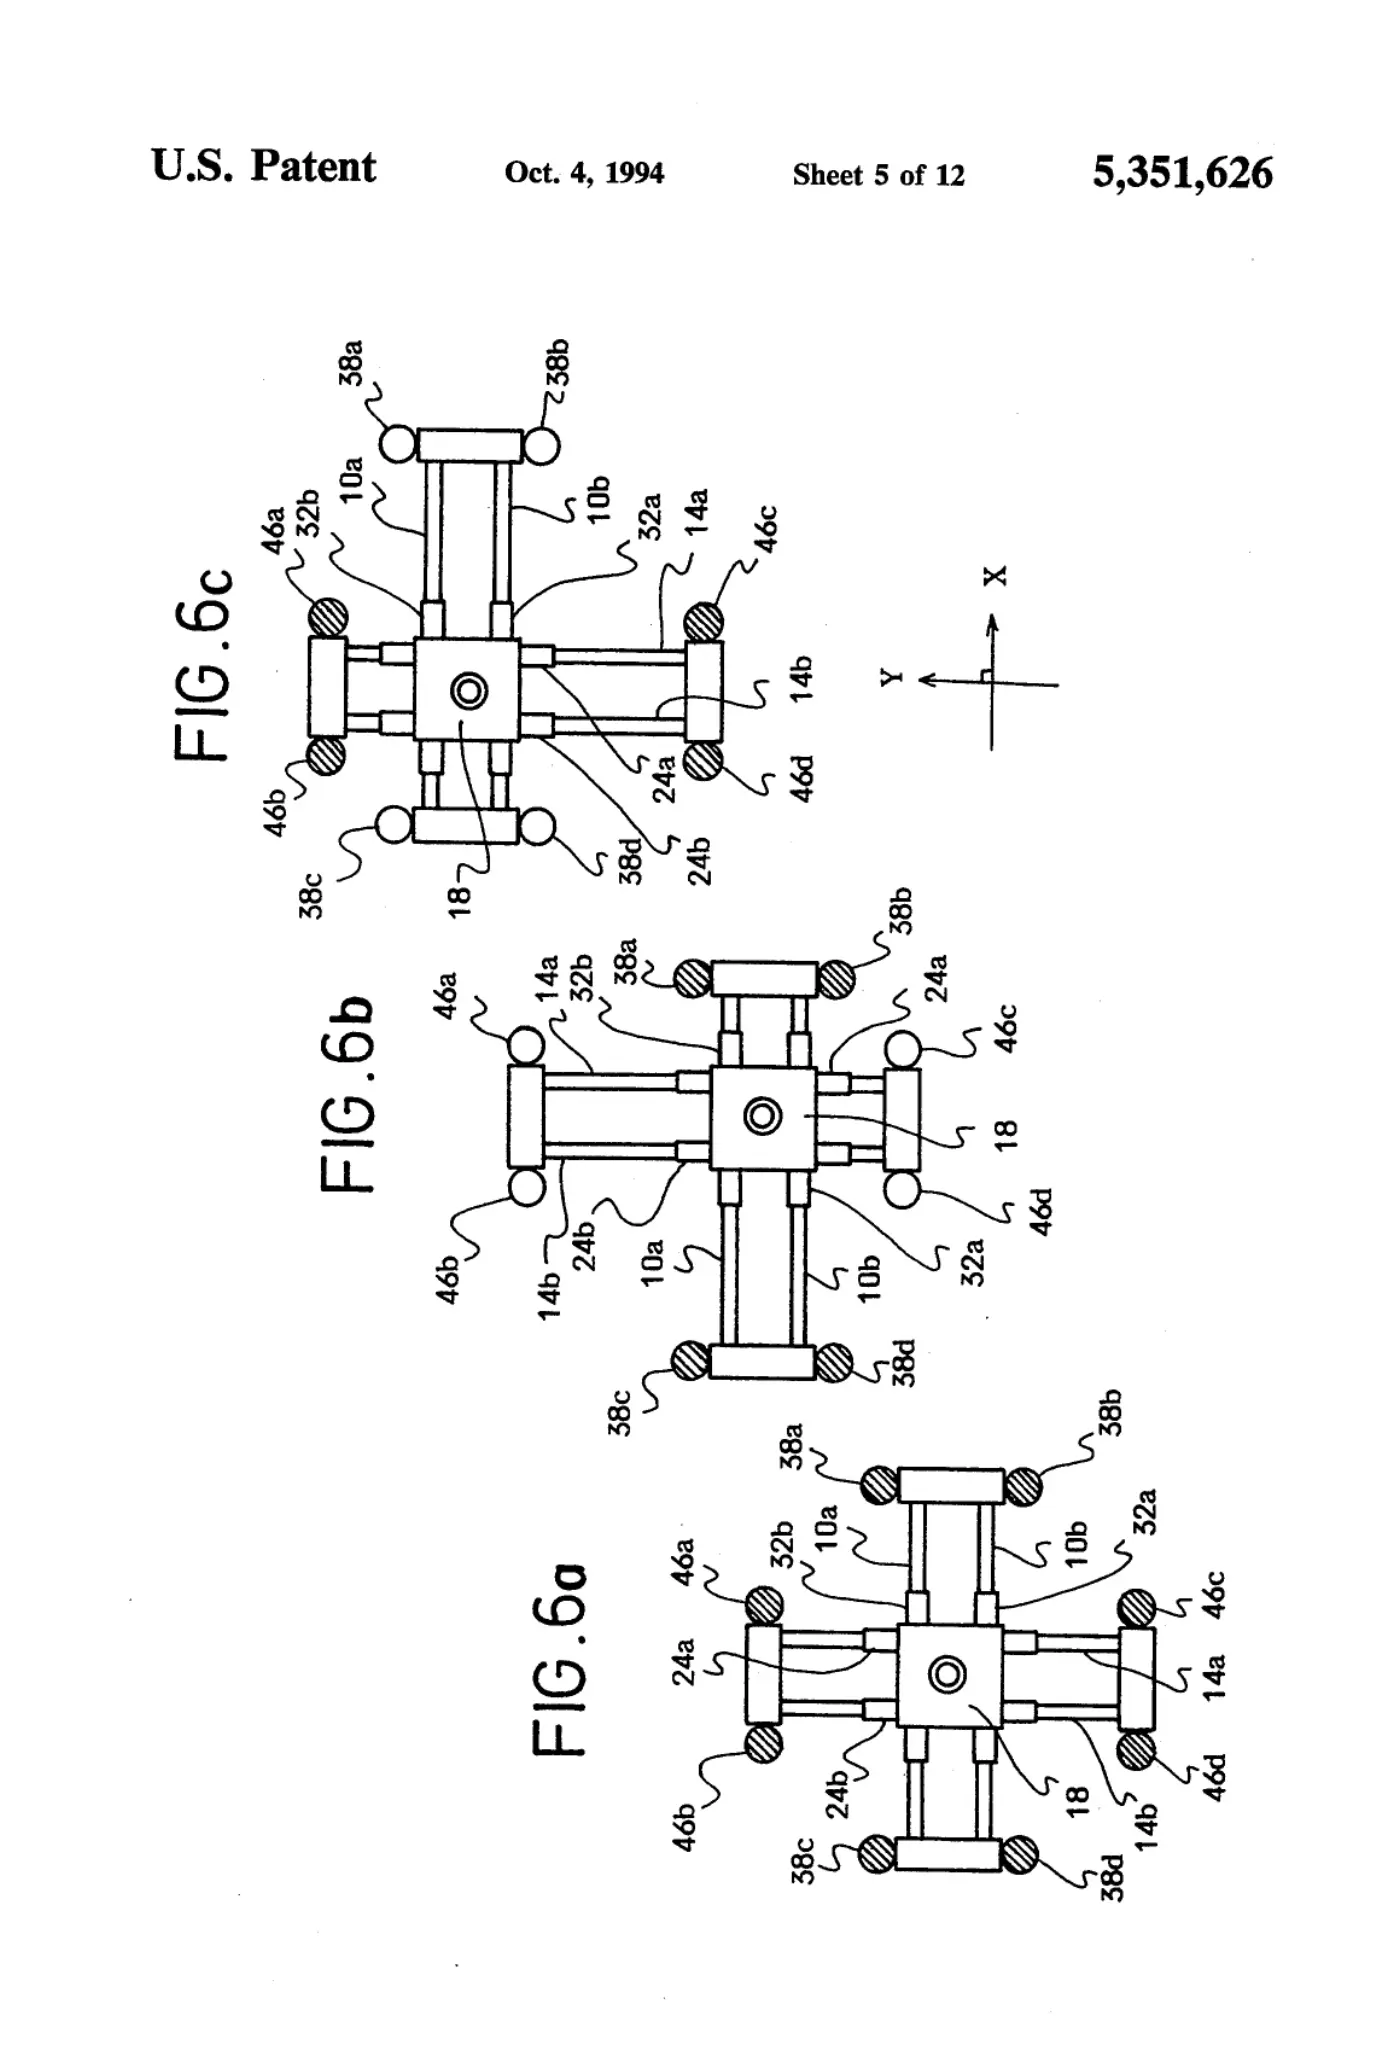
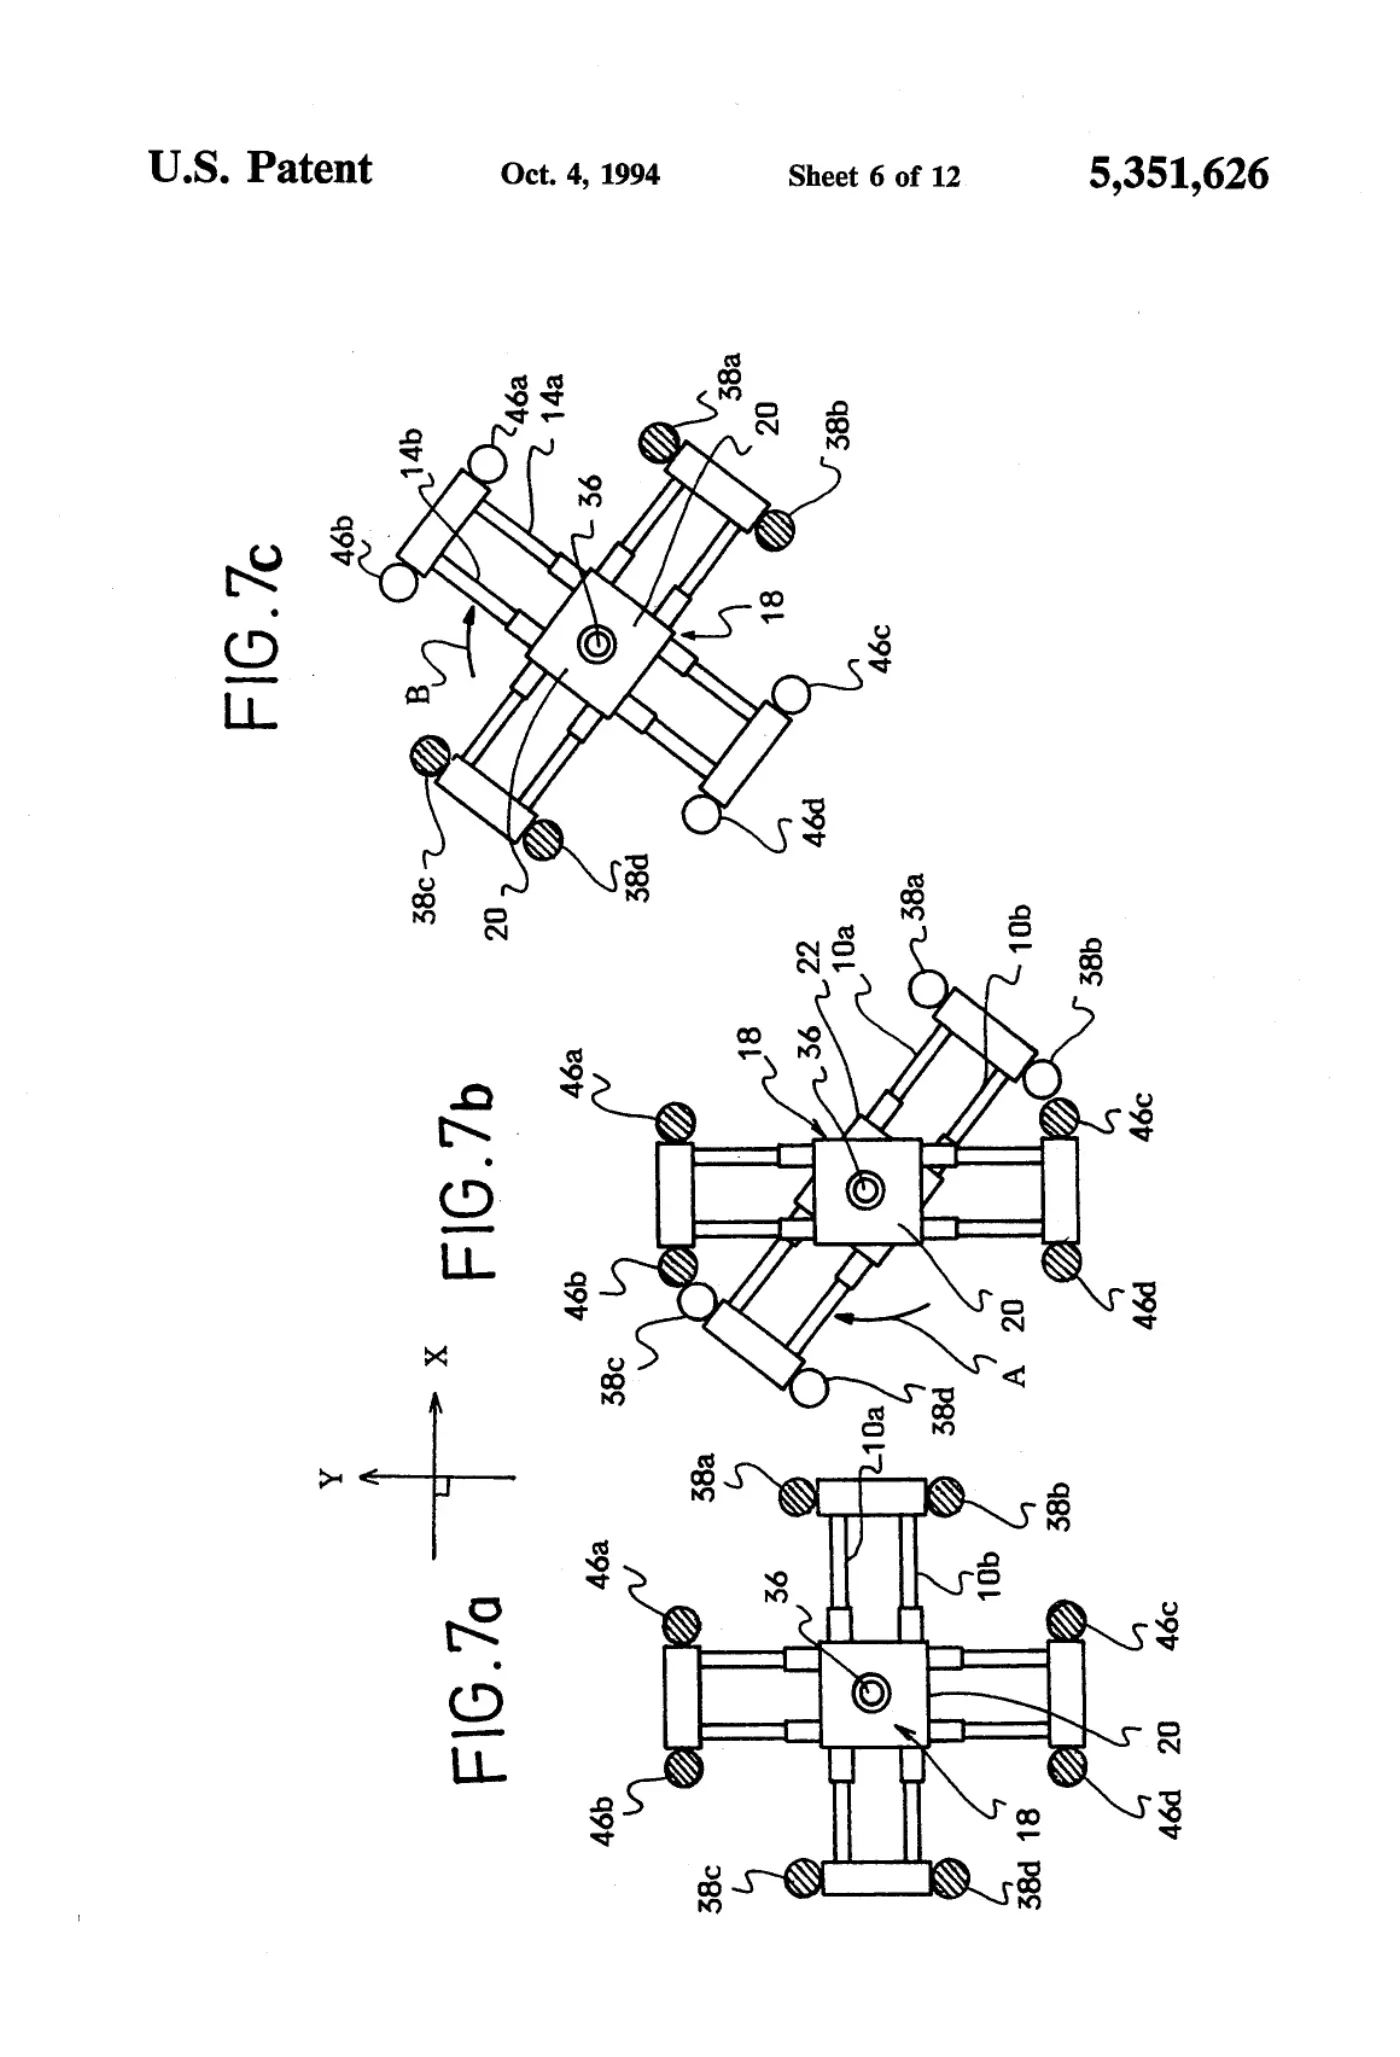
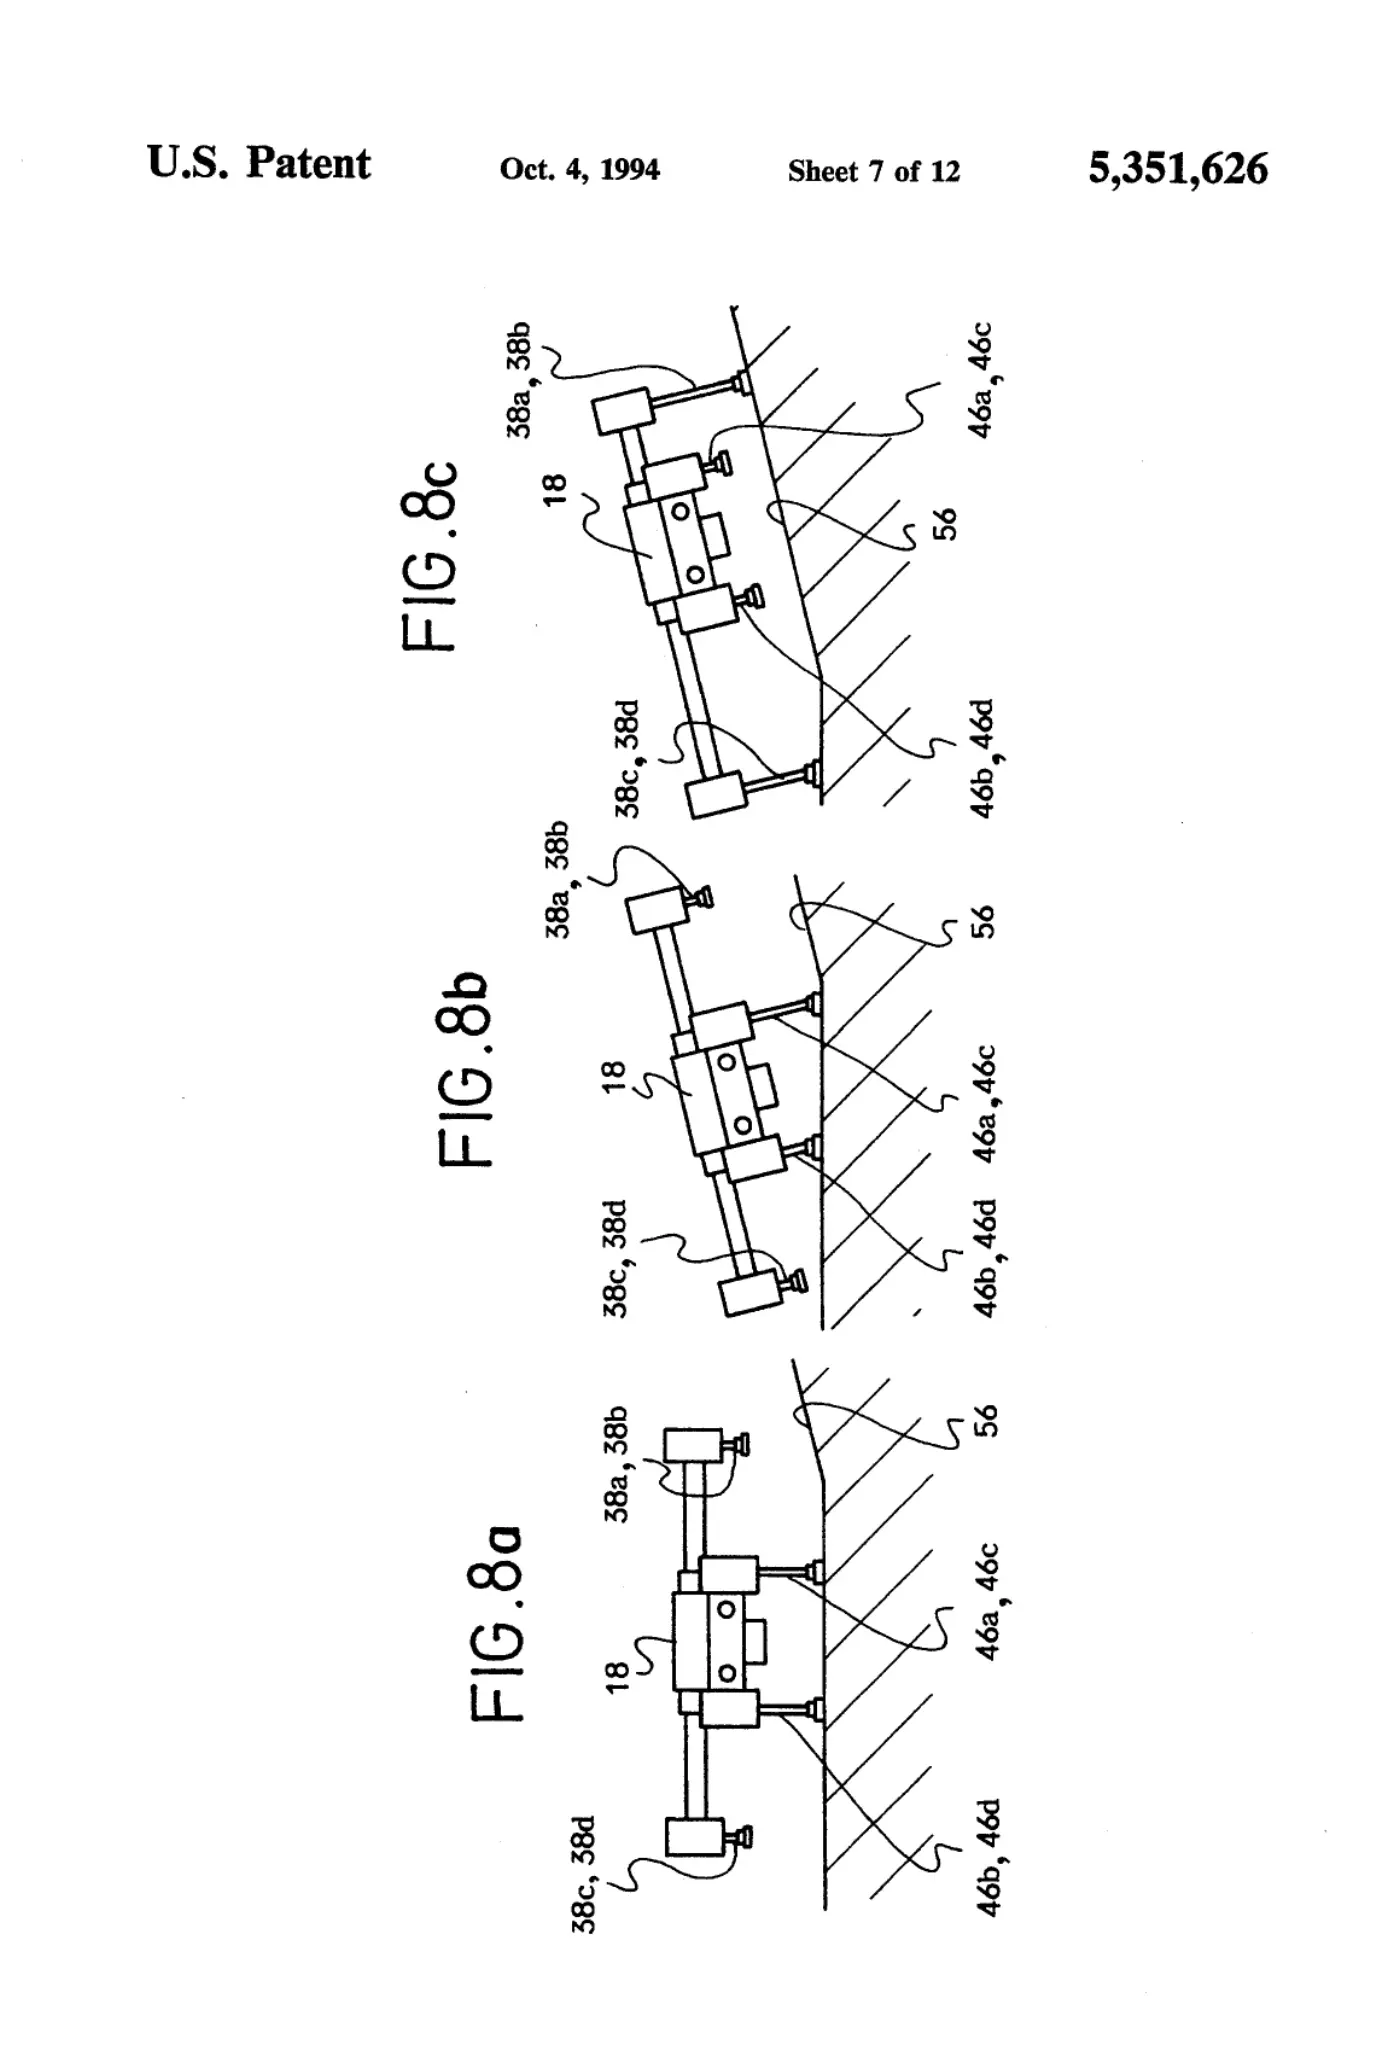
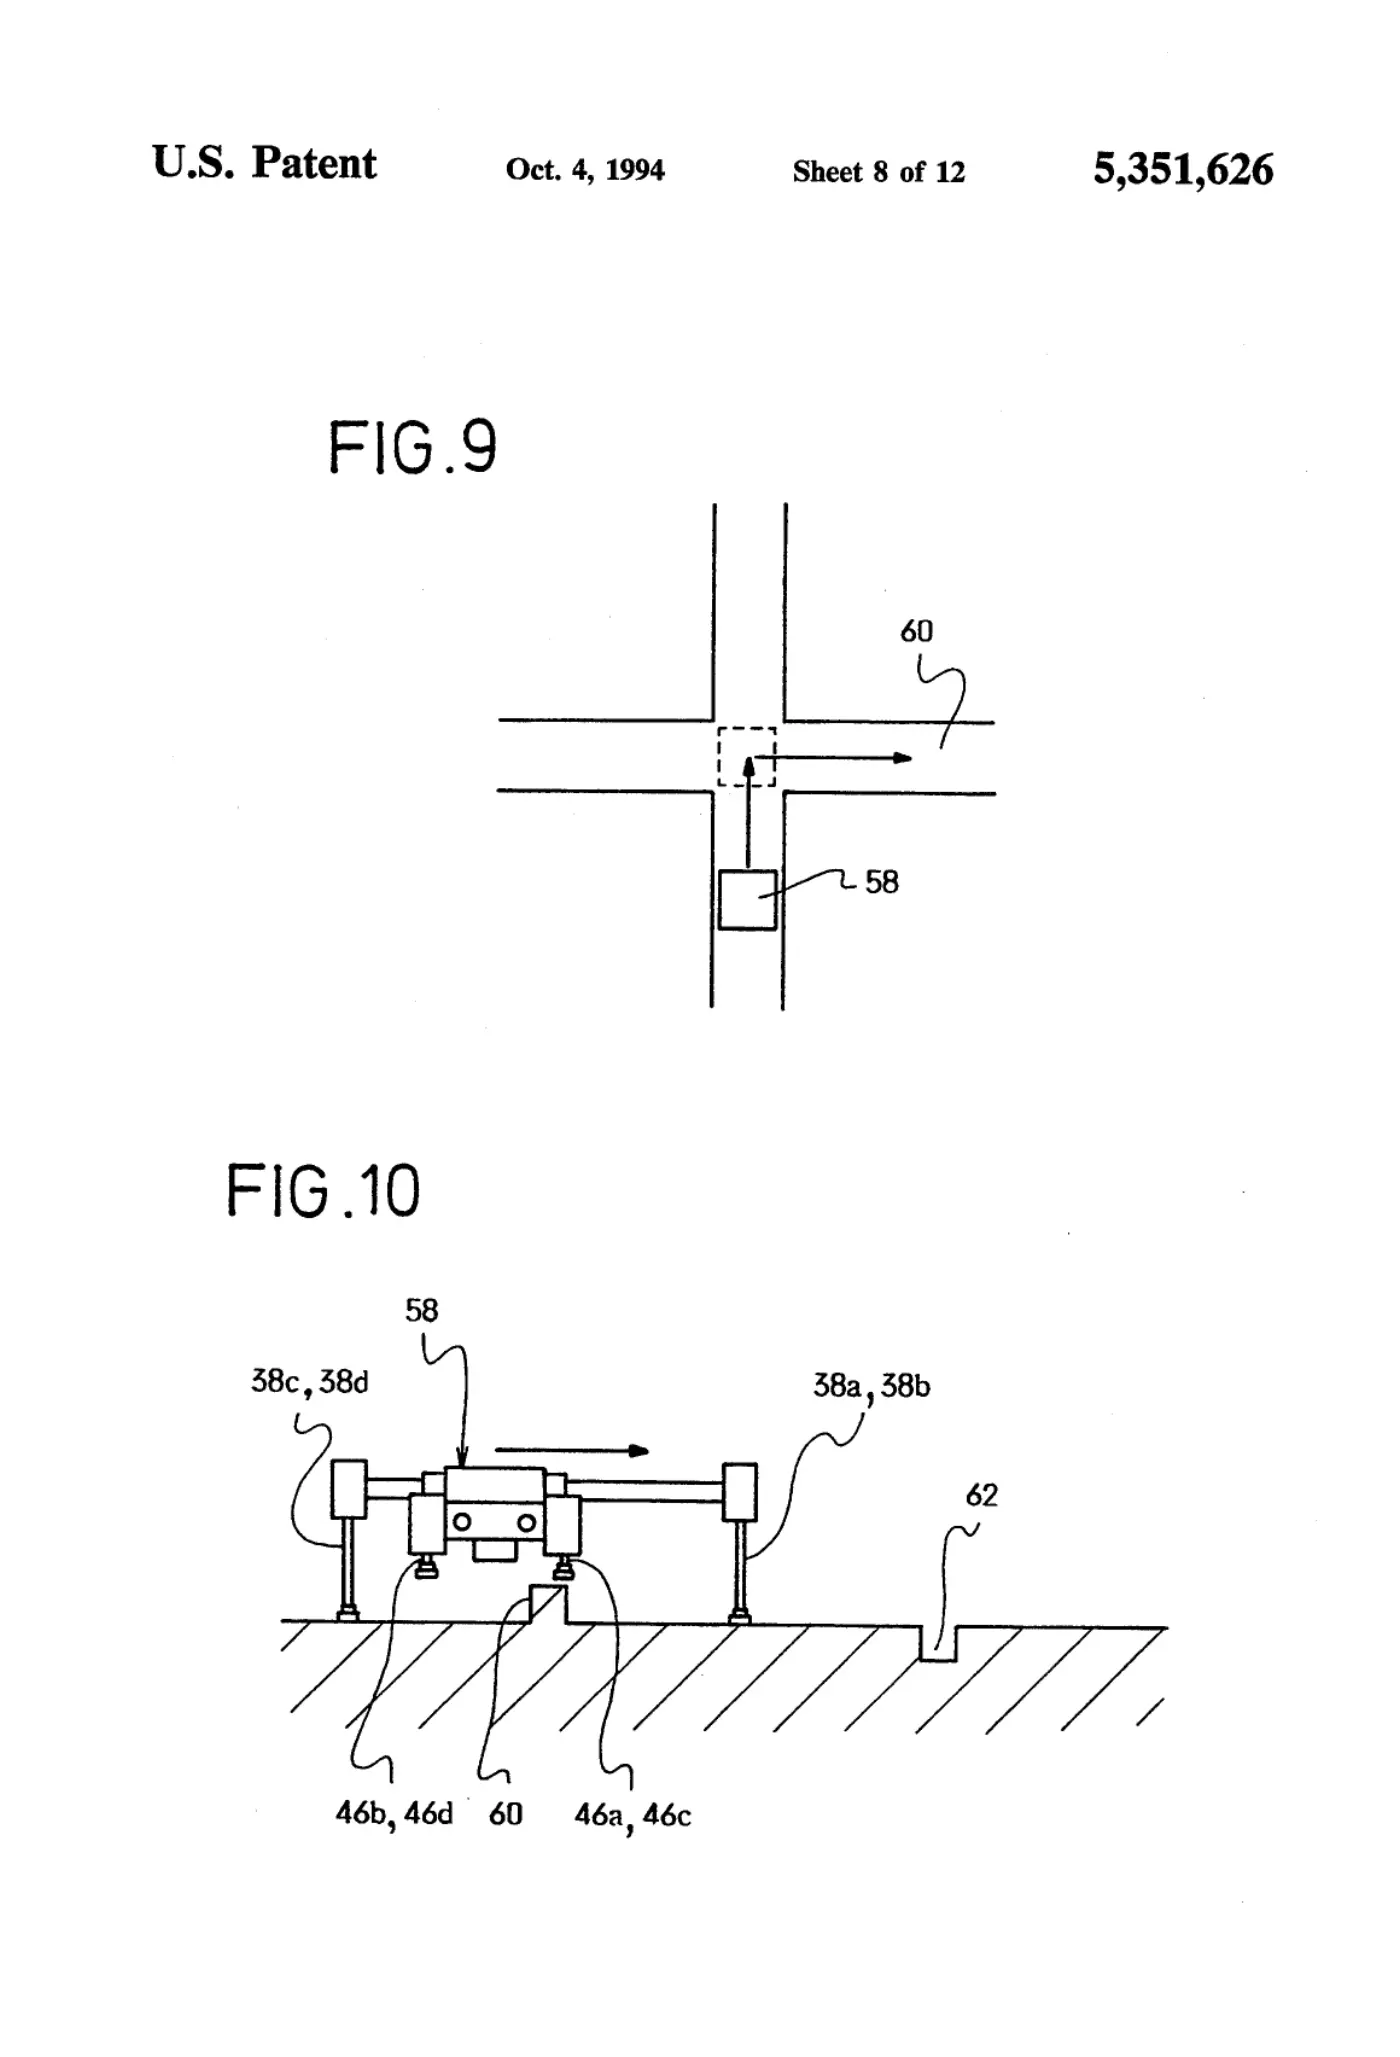
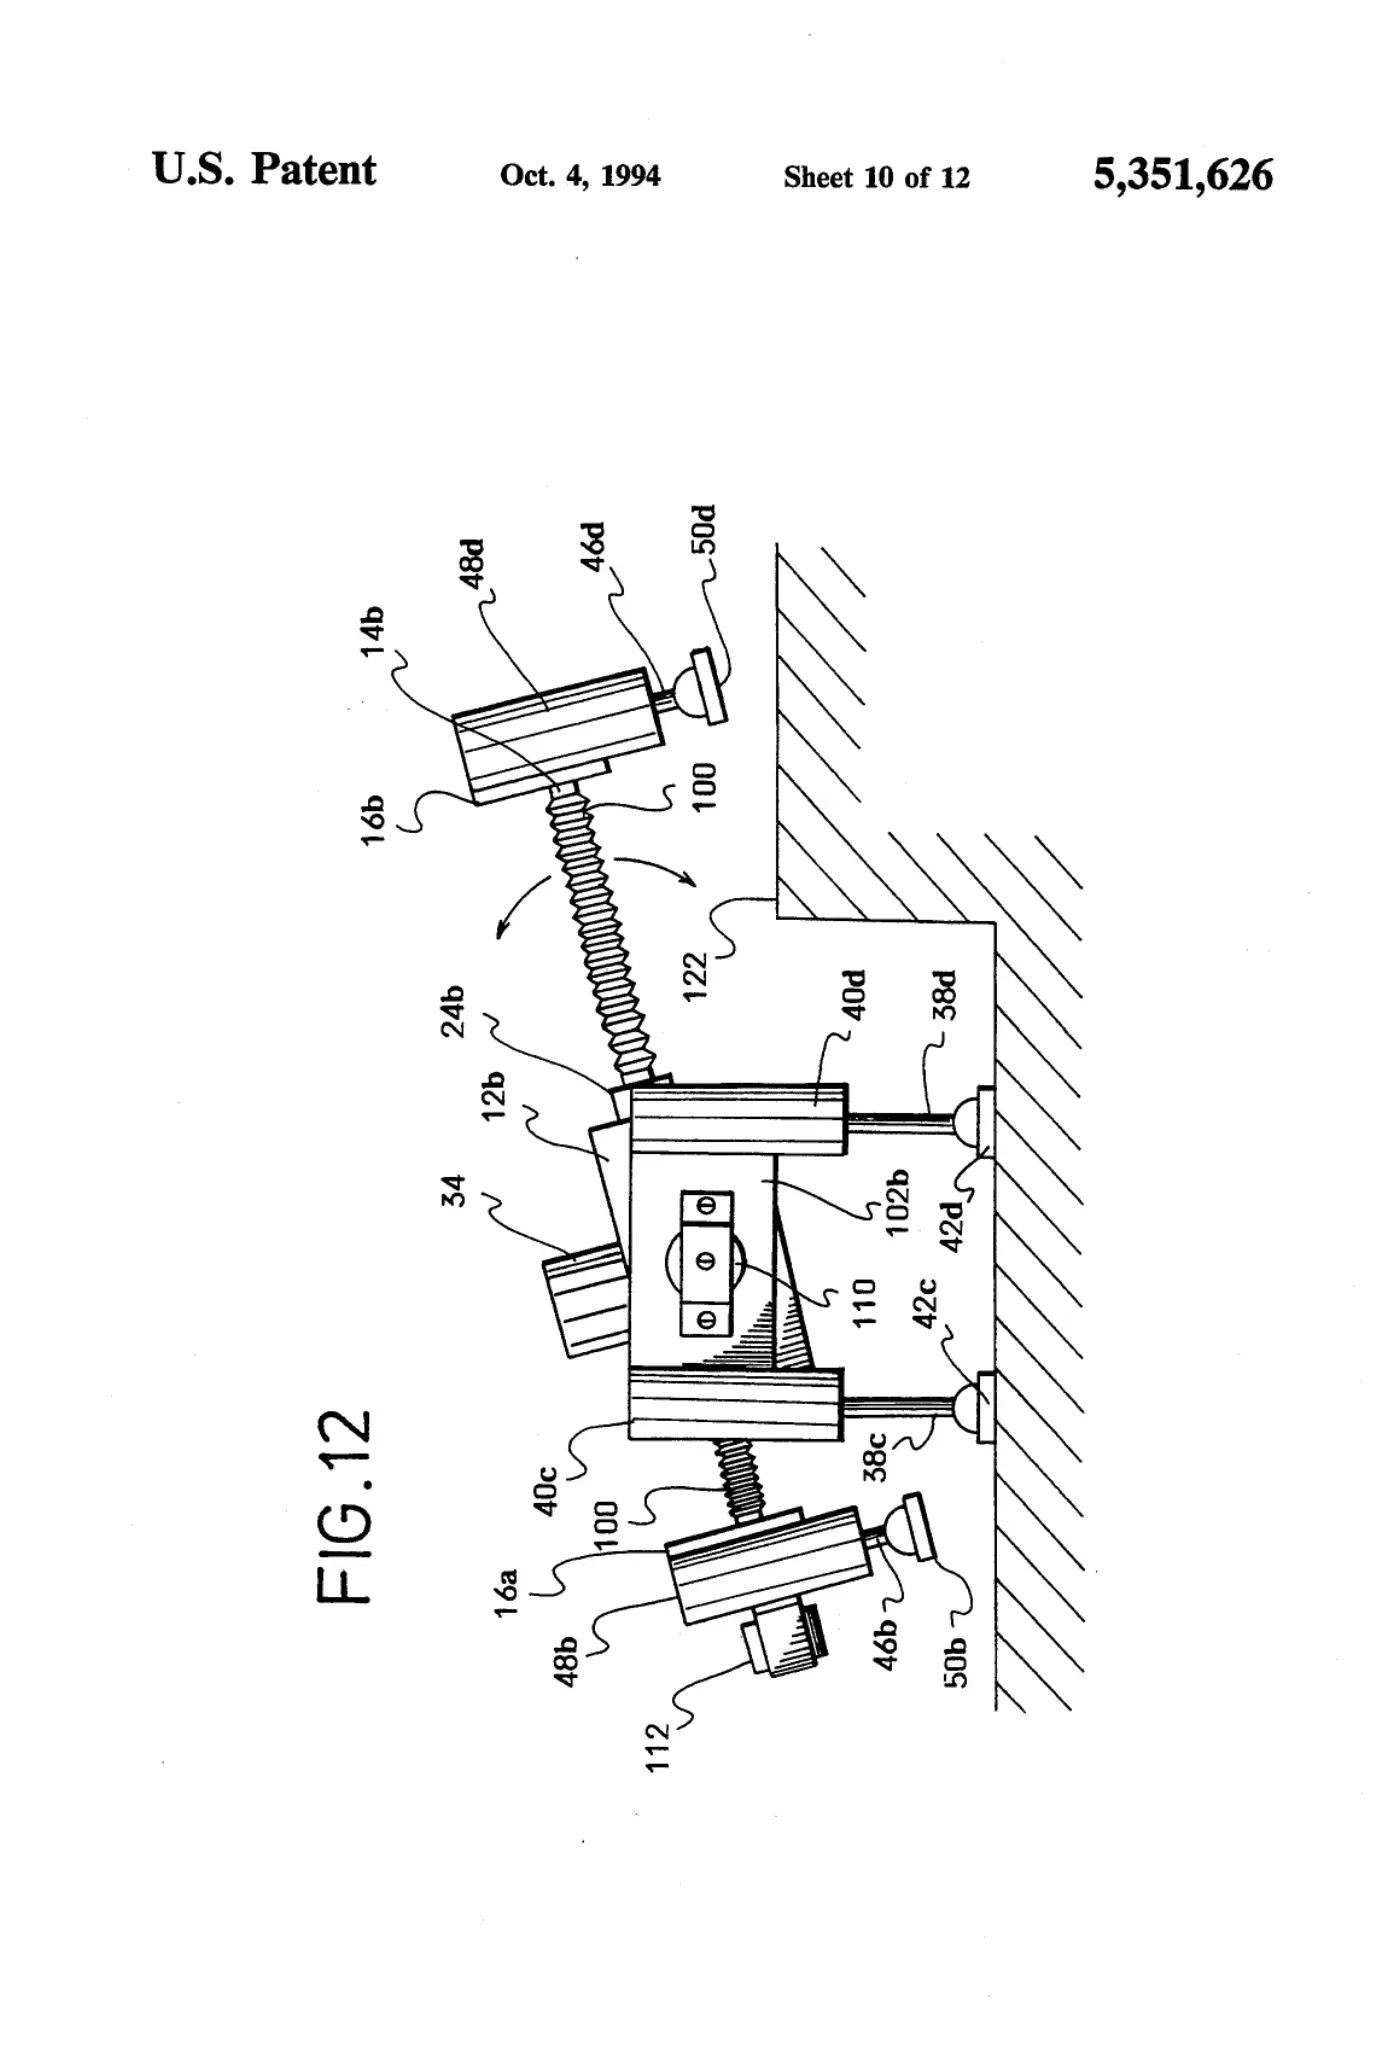
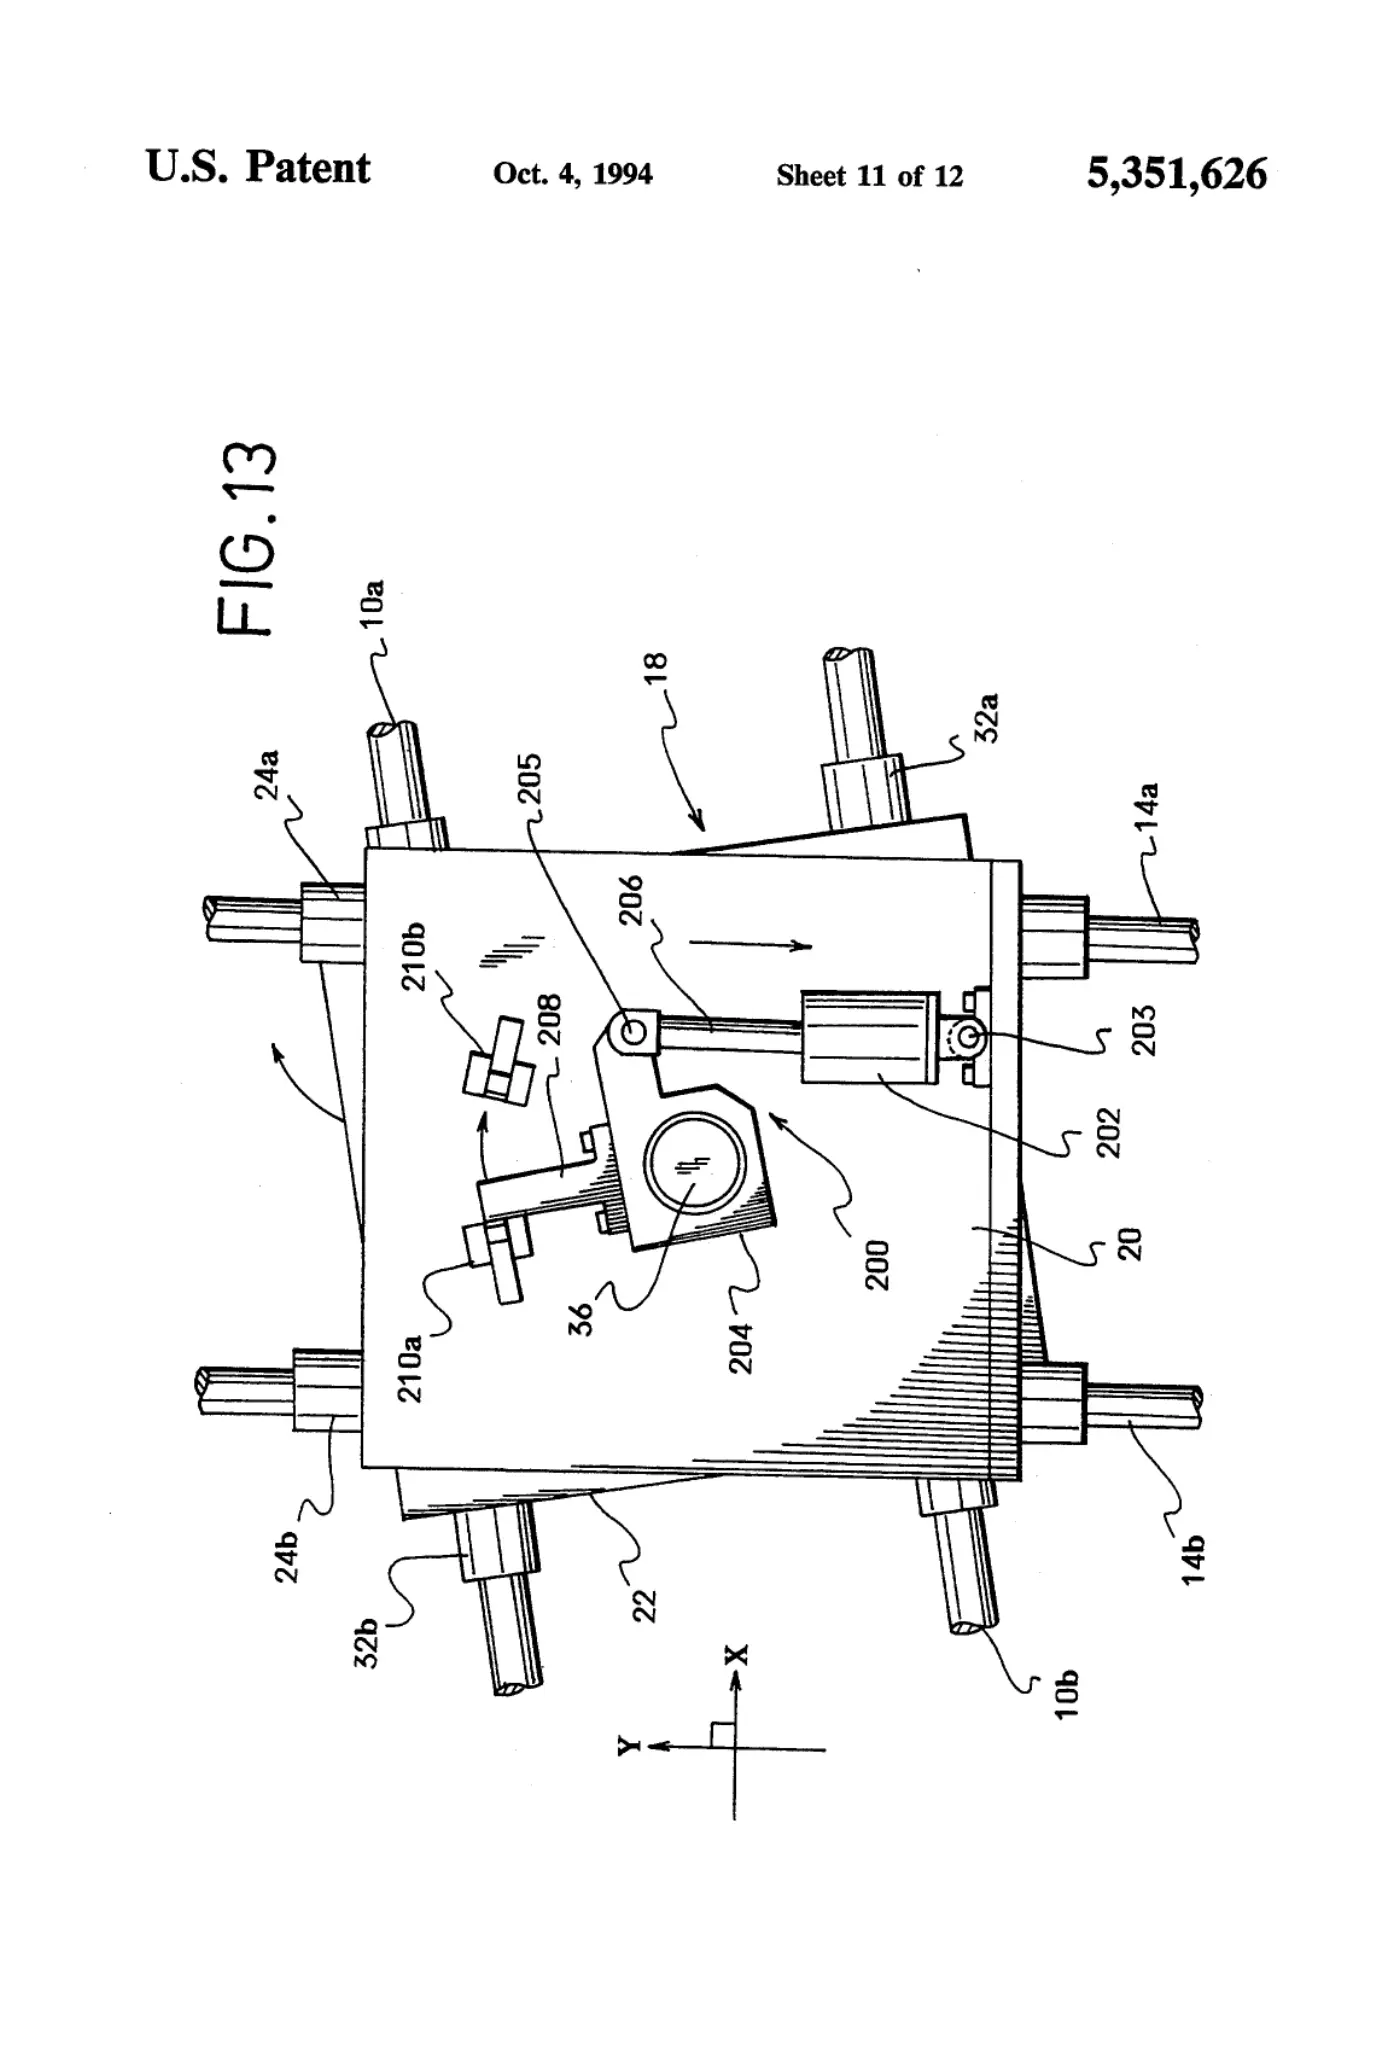
The present invention relates to a walking robot. The robot includes: an X-elongated member; a Y-elongated member; a moving body moving on the X- and Y-elongated members; an X-leg section provided to the X-elongated member, the X-leg section being capable of extending and shortening in the Z-direction; a Y-leg section being provided to the Y-elongated member, the Y-leg section being capable of extending and shortening in the Z-direction; an X-driving mechanism for moving the moving body in the X-direction; a Y-driving mechanism for moving the moving body in the Y-direction; a first Z-driving mechanism for extending and shortening the X-leg section; and a second Z-driving mechanism for extending and shortening the Y-leg section. With this structure, the robot is able to stride over obstructions by extending the X- and the Y-leg sections so as to avoid interference without changing course.
Abstract
The present invention relates to a walking robot. The robot includes: an X-elongated member; a Y-elongated member; a moving body moving on the X- and Y-elongated members; an X-leg section provided to the X-elongated member, the X-leg section being capable of extending and shortening in the Z-direction; a Y-leg section being provided to the Y-elongated member, the Y-leg section being capable of extending and shortening in the Z-direction; an X-driving mechanism for moving the moving body in the X-direction; a Y-driving mechanism for moving the moving body in the Y-direction; a first Z-driving mechanism for extending and shortening the X-leg section; and a second Z-driving mechanism for extending and shortening the Y-leg section. With this structure, the robot is able to stride over obstructions by extending the X- and the Y-leg sections so as to avoid interference without changing course.
1. Drawings
[0001]Sheet 1.
[0002]Sheet 2.
[0003]Sheet 3.
[0004]Sheet 4.
[0005]Sheet 5.
[0006]Sheet 6.
[0007]Sheet 7.
[0008]Sheet 8.
[0009]Sheet 9.
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003334, “Walking robot,” published September 15, 2026 at 20:11:47 UTC, https://opentechnical.org/p/OT-2026-000003334.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.