OT-2026-000003367
Manipulator with a suction gripper and method for handling and testing fluid-passing components
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003367
- Classification
- Robotics & Automation › Robot Architectures
- Inventors
- COHANCIUC VICTOR, GOEDECKE WOLF-DIETER
- Assignee
- MANNESMANN AG
- Original source
- US-5244242-A, the United States Patent and Trademark Office, 14 September 1993
- Document SHA-256
- 98ab6a4a7b2508b188240851734a66561863554641447d95bf0f5db0991976b6
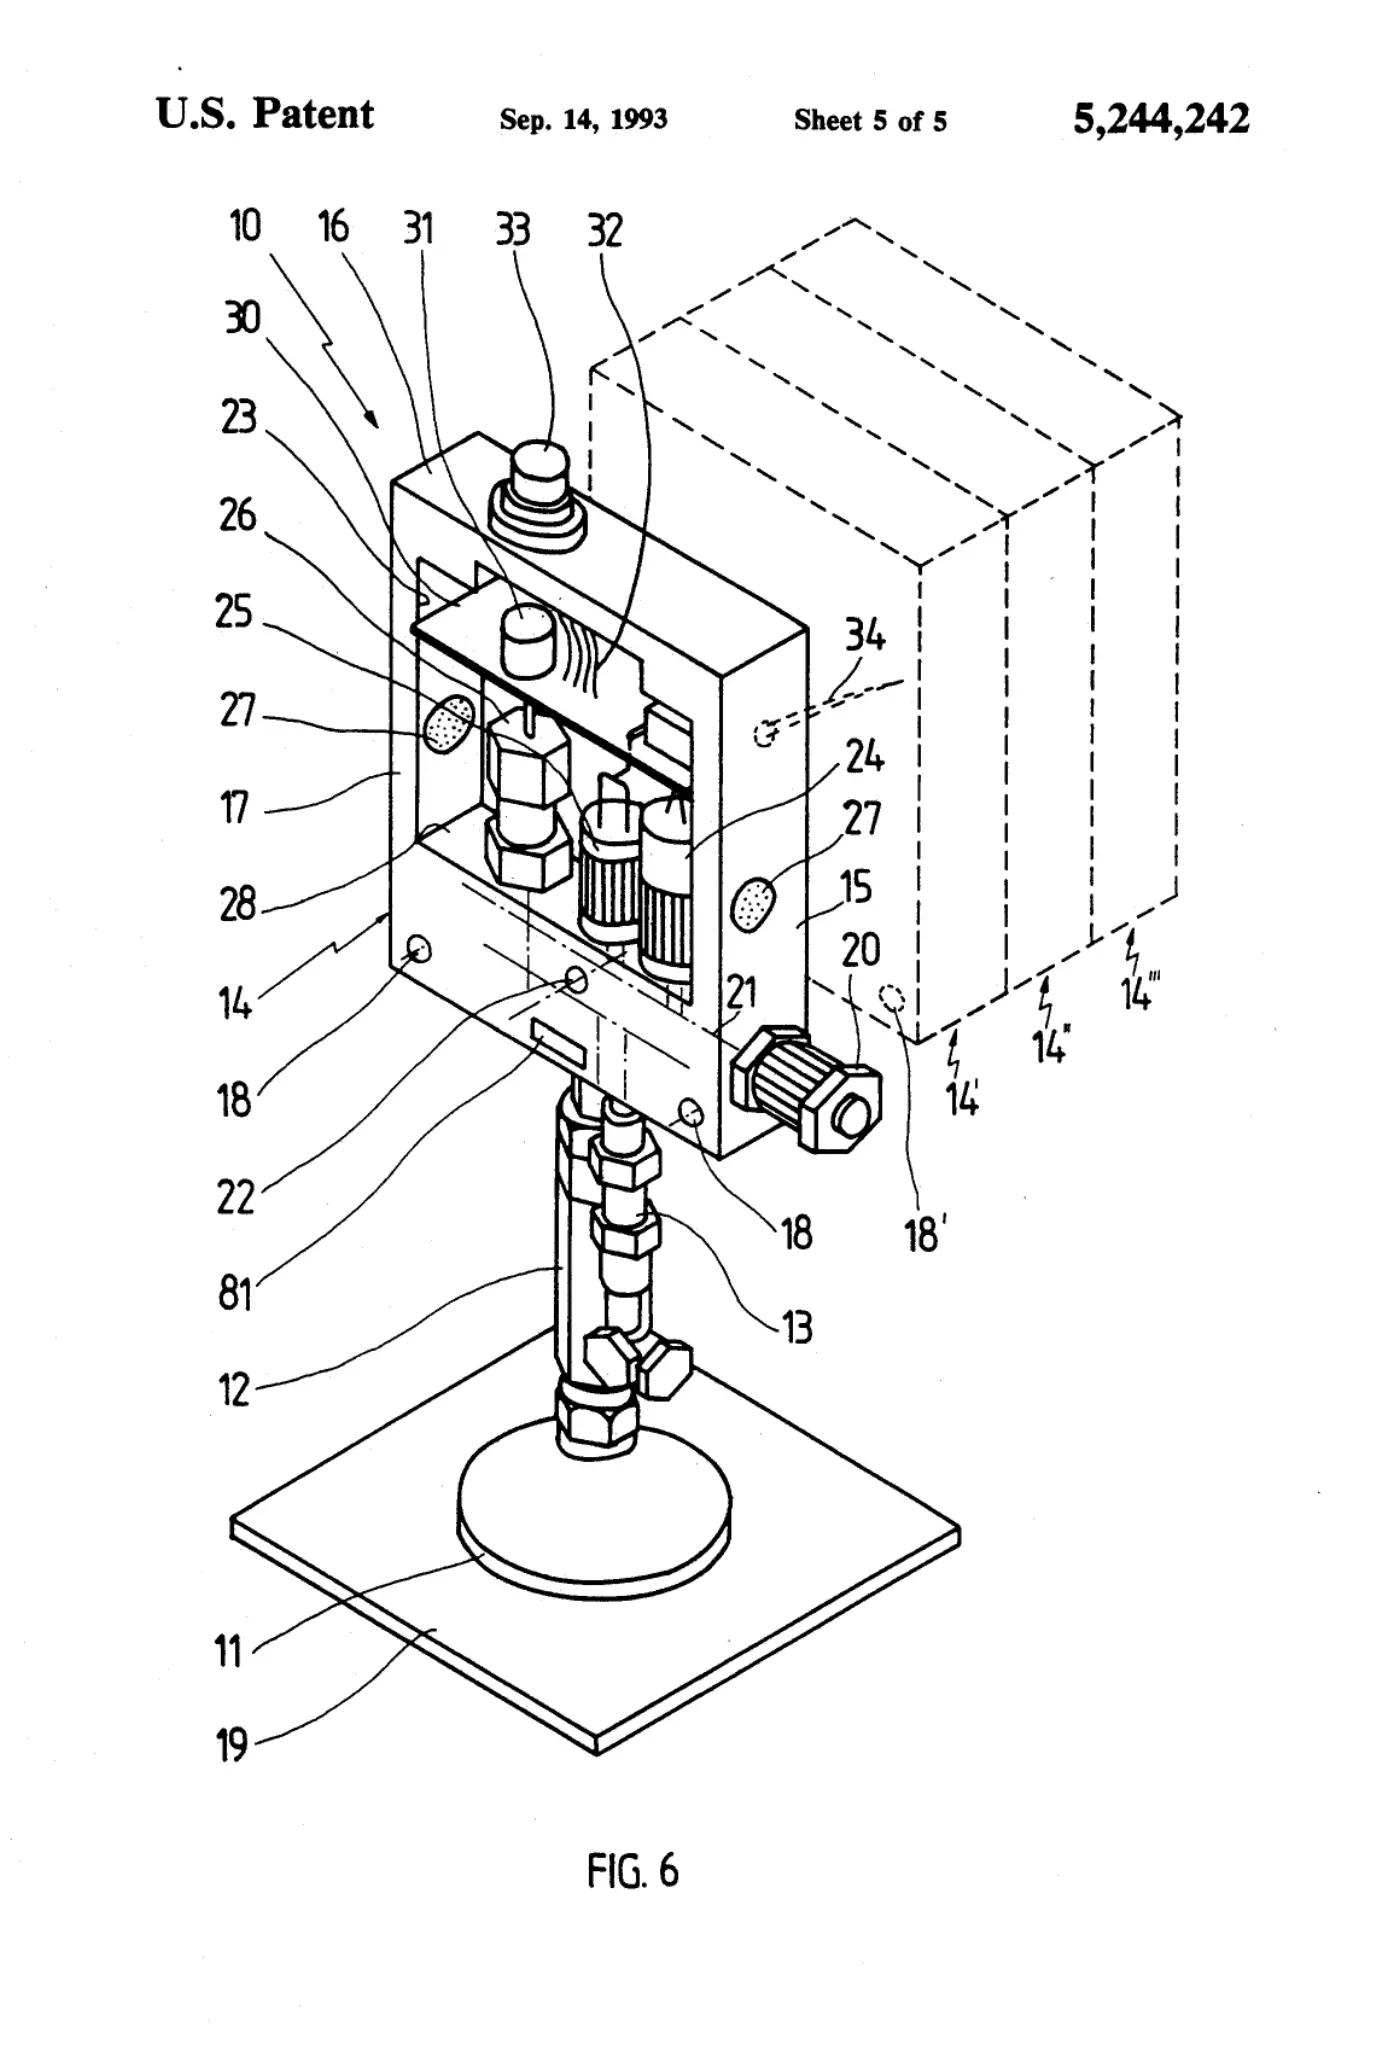
A manipulating device includes a gripper (11) for gripping workpieces (19) by way of a negative pressure. A suction pump for generating and feeding the negative pressure as well as at least one valve (24) are disposed in a casing (14). The casing is connected with the suction gripper (11). The negative pressure can be applied to the suction gripper (11) by means of the valve (24).
Abstract
A manipulating device includes a gripper (11) for gripping workpieces (19) by way of a negative pressure. A suction pump for generating and feeding the negative pressure as well as at least one valve (24) are disposed in a casing (14). The casing is connected with the suction gripper (11). The negative pressure can be applied to the suction gripper (11) by means of the valve (24).
1. Drawings
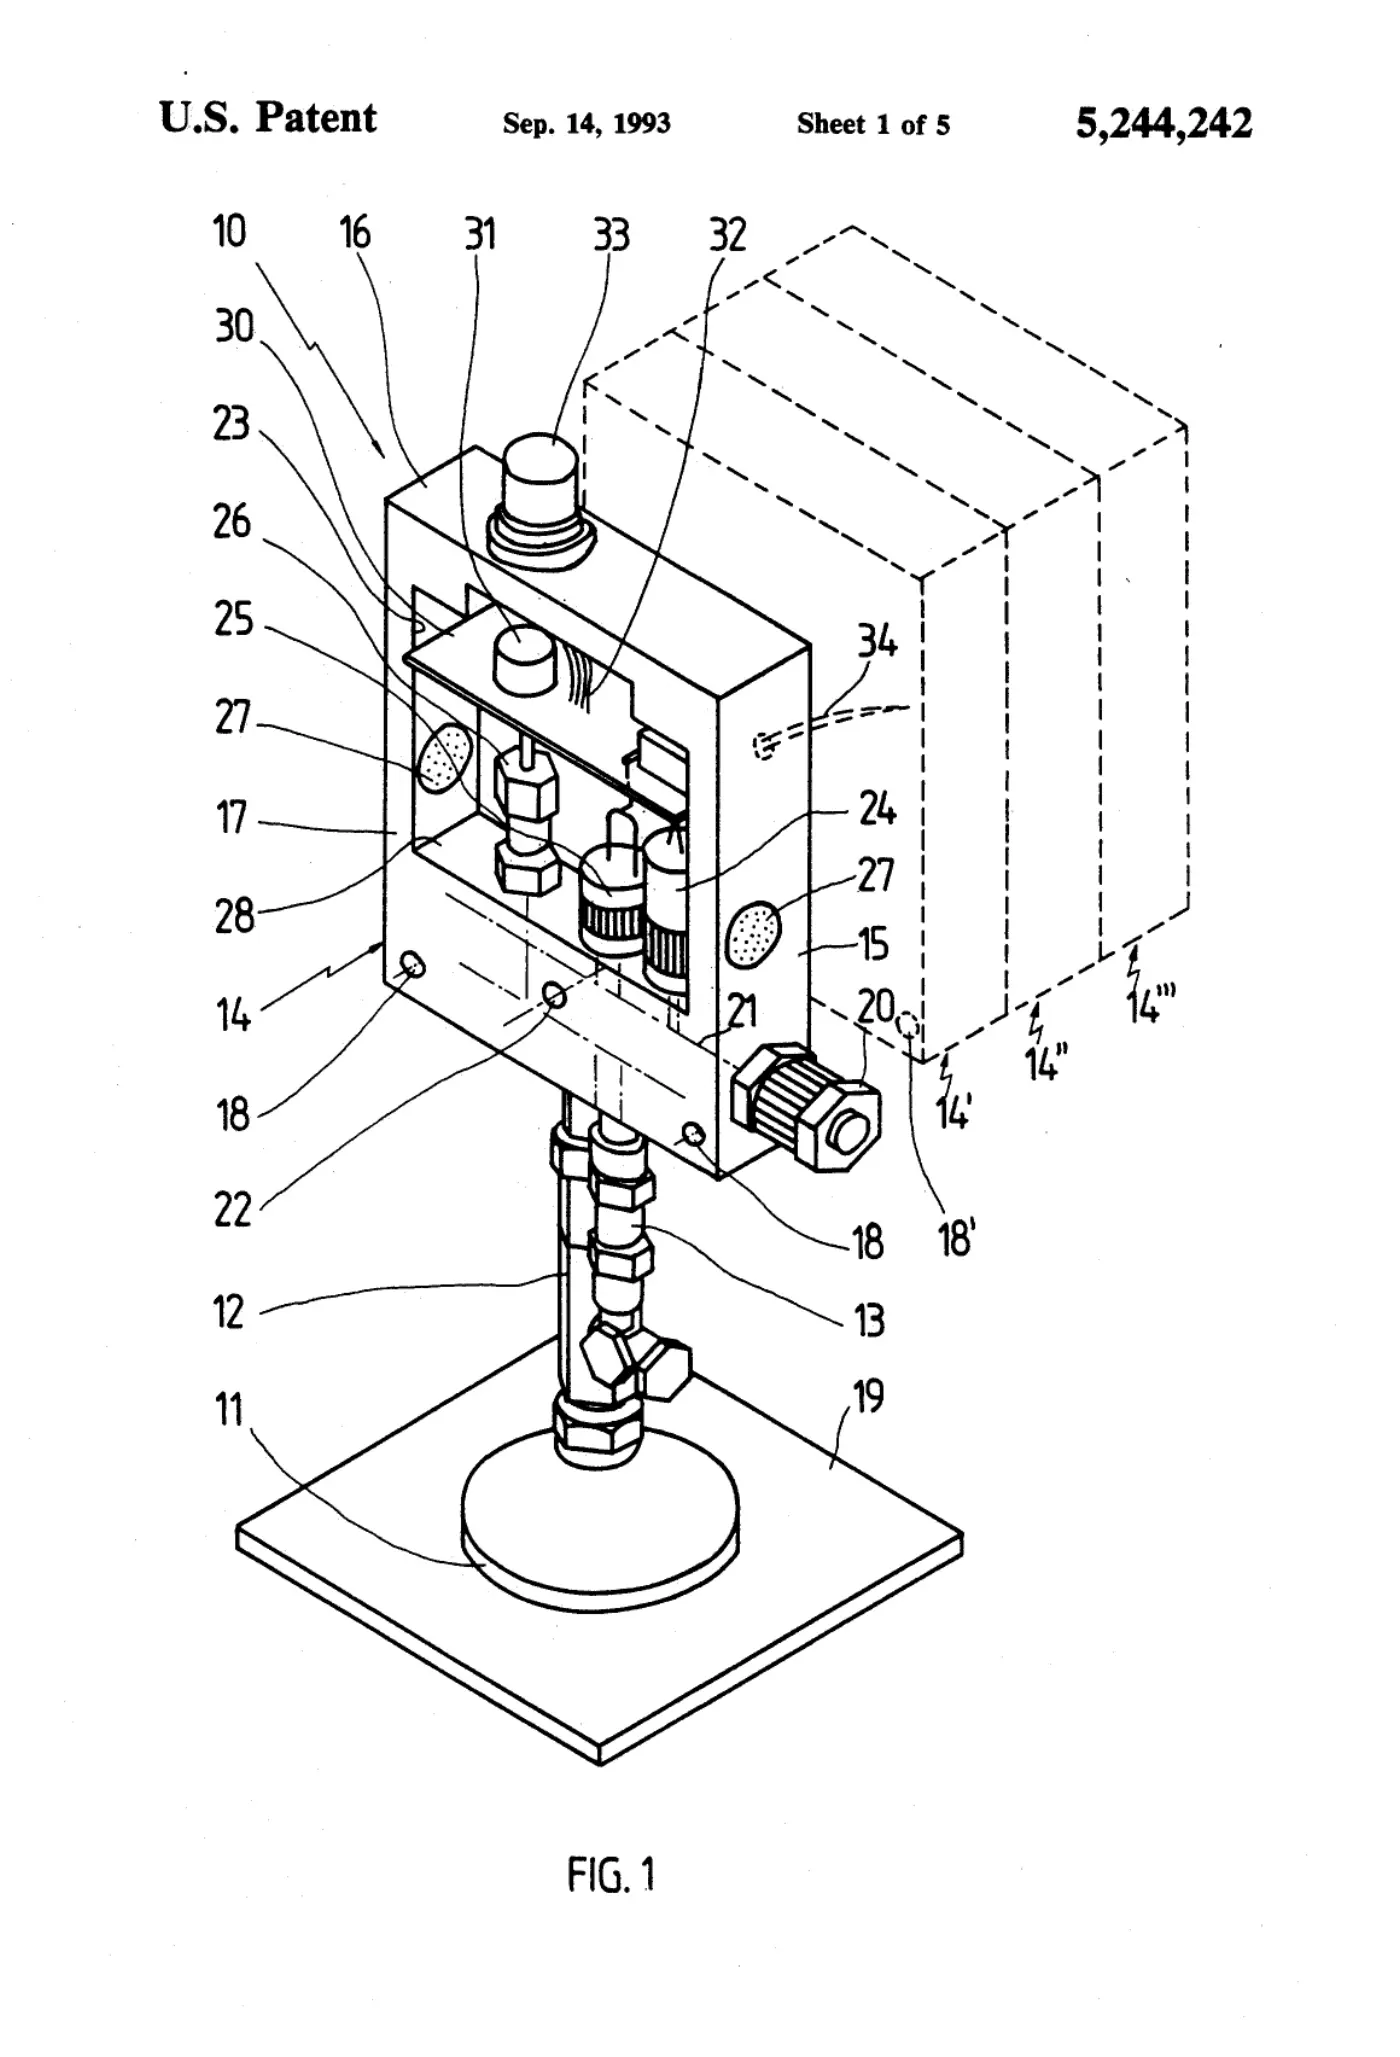
[0001]Sheet 1.
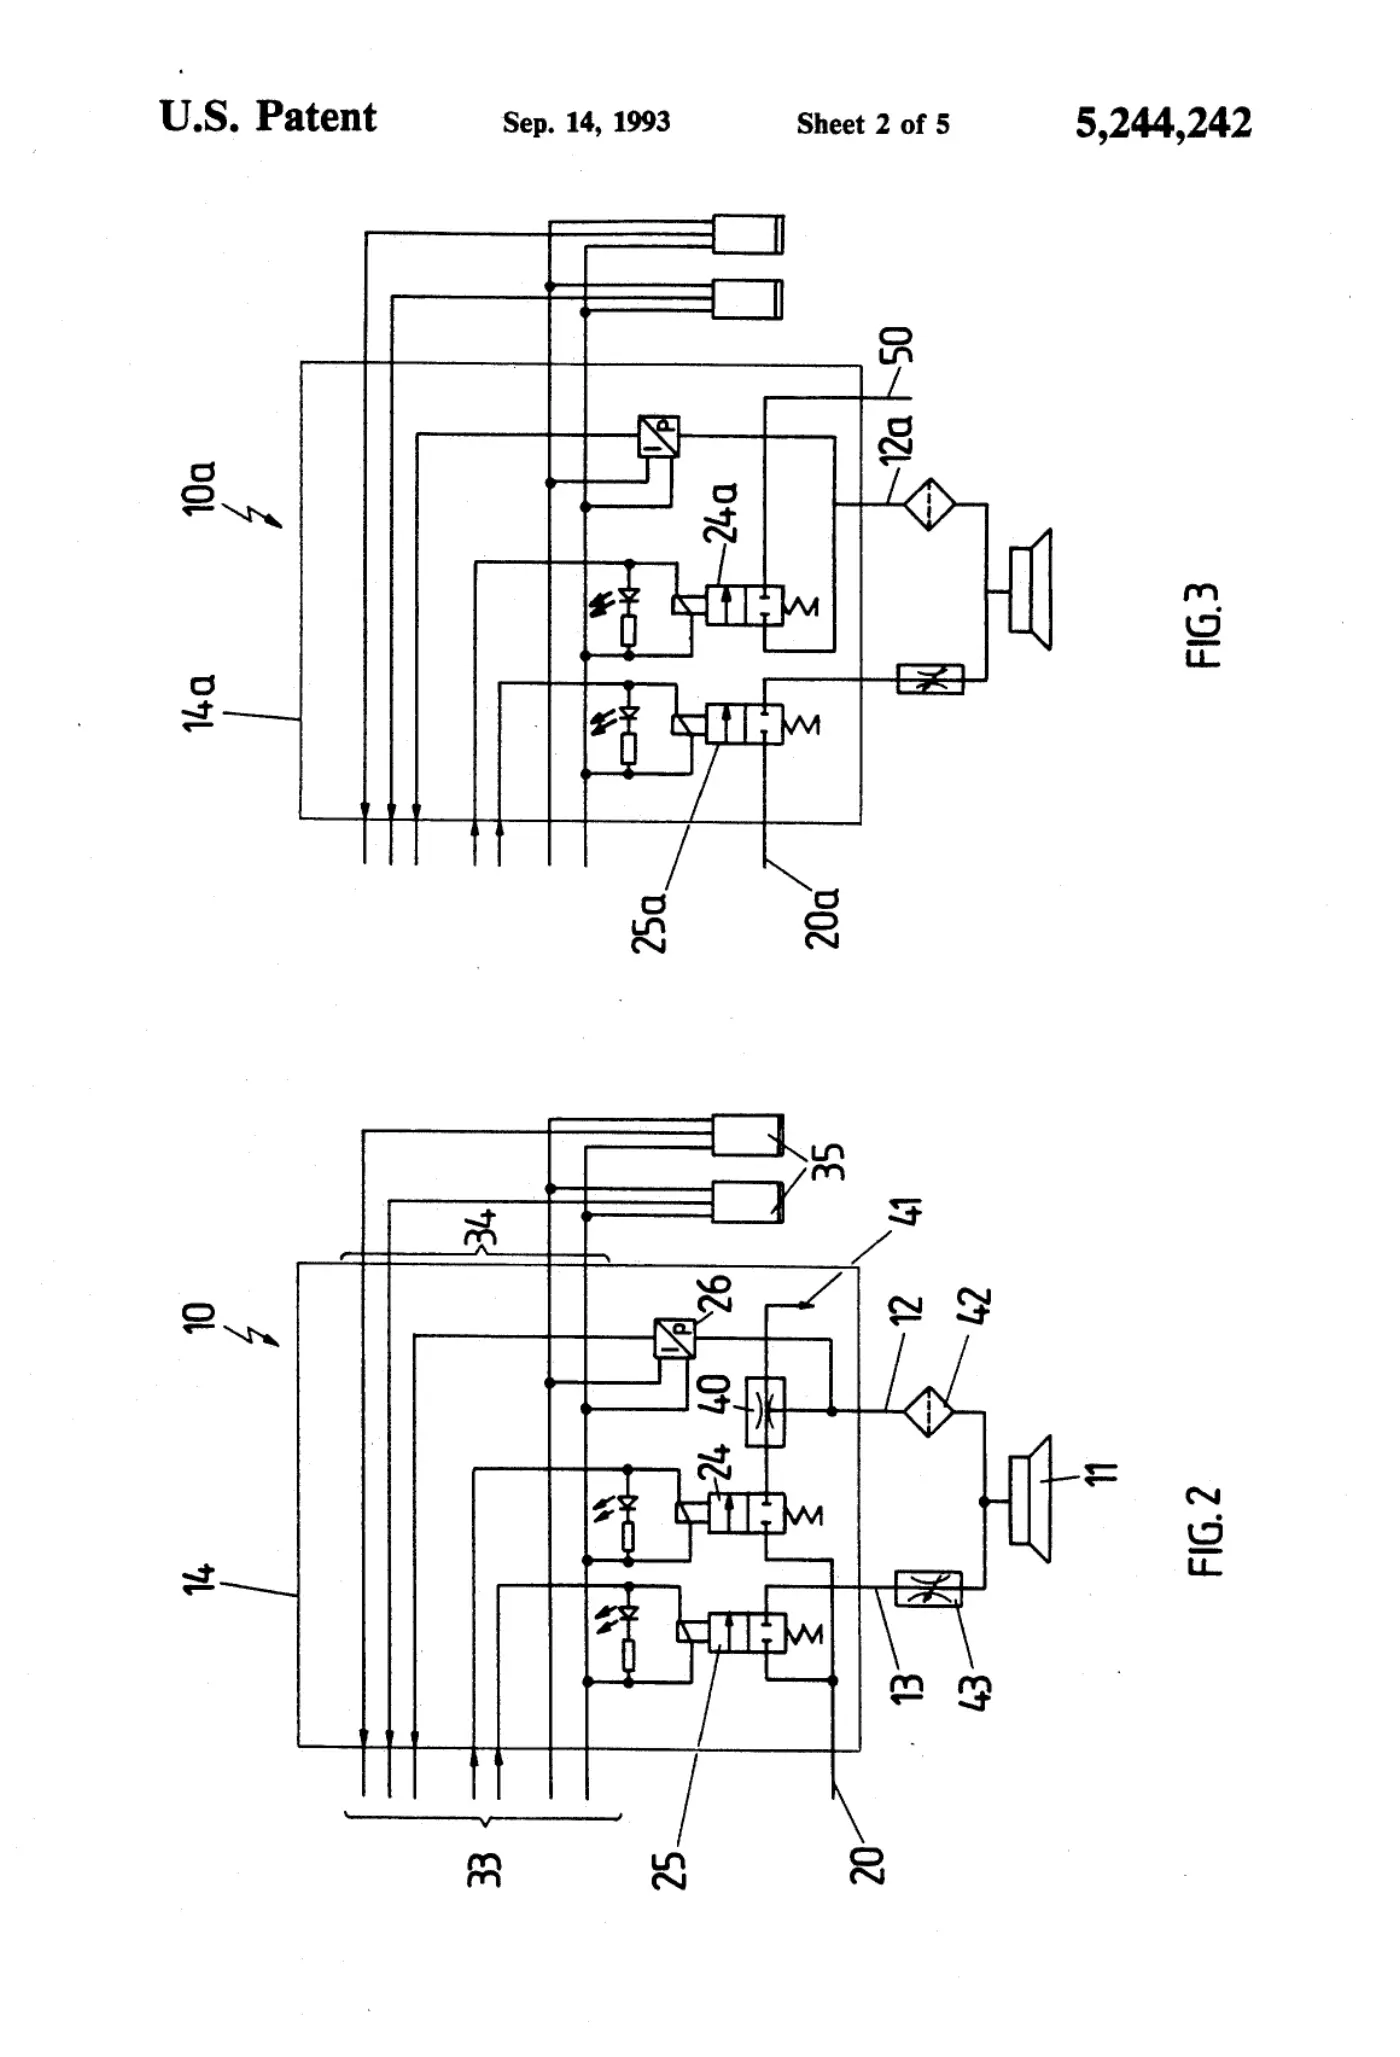
[0002]Sheet 2.
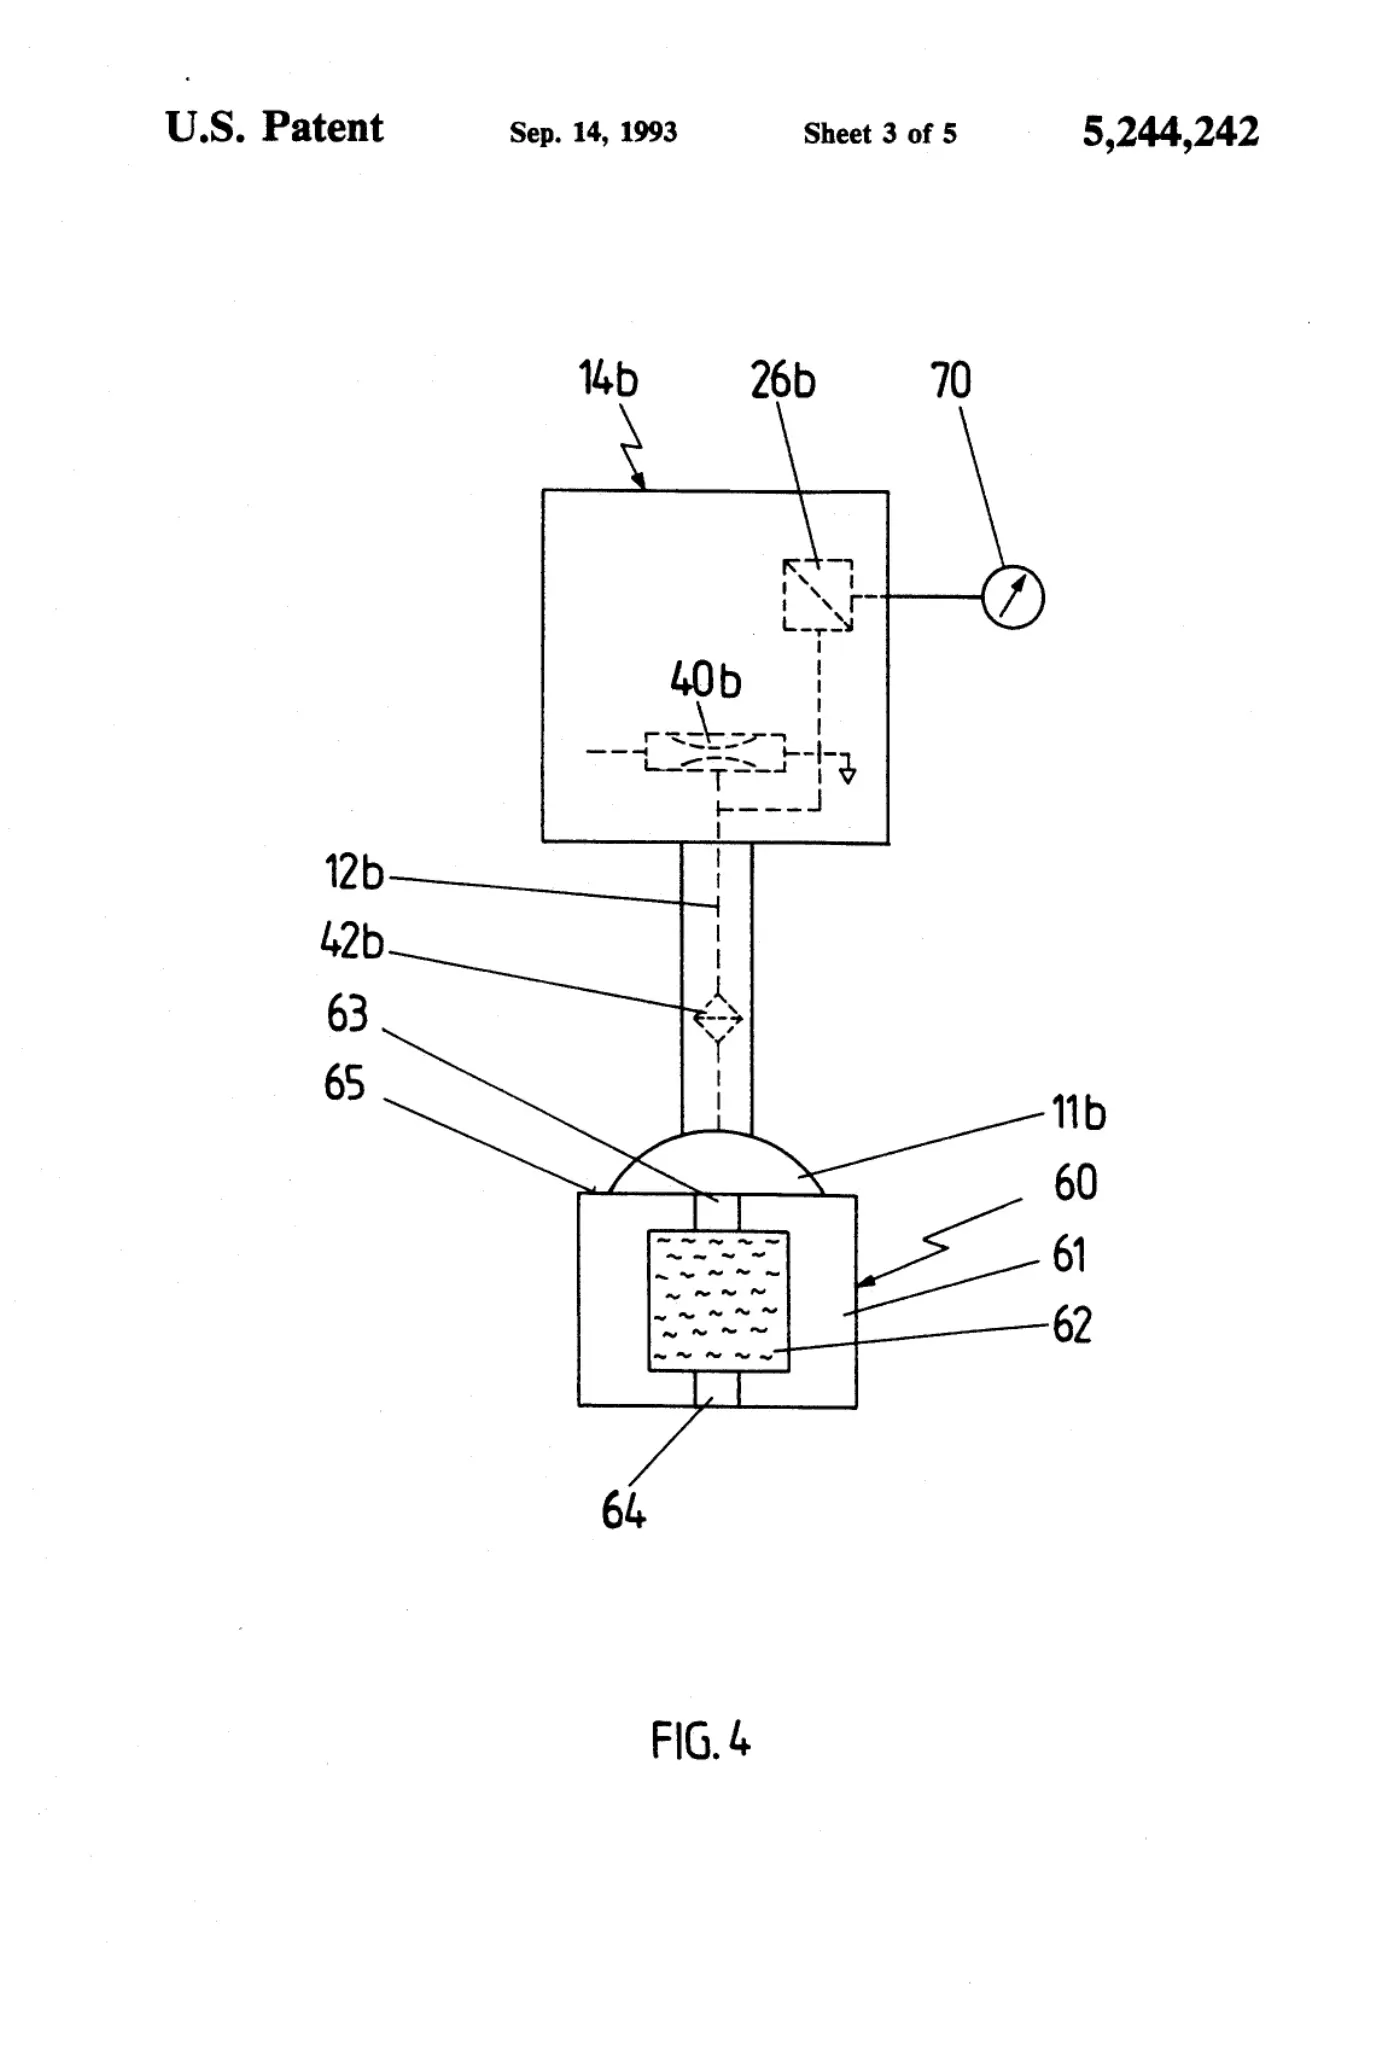
[0003]Sheet 3.
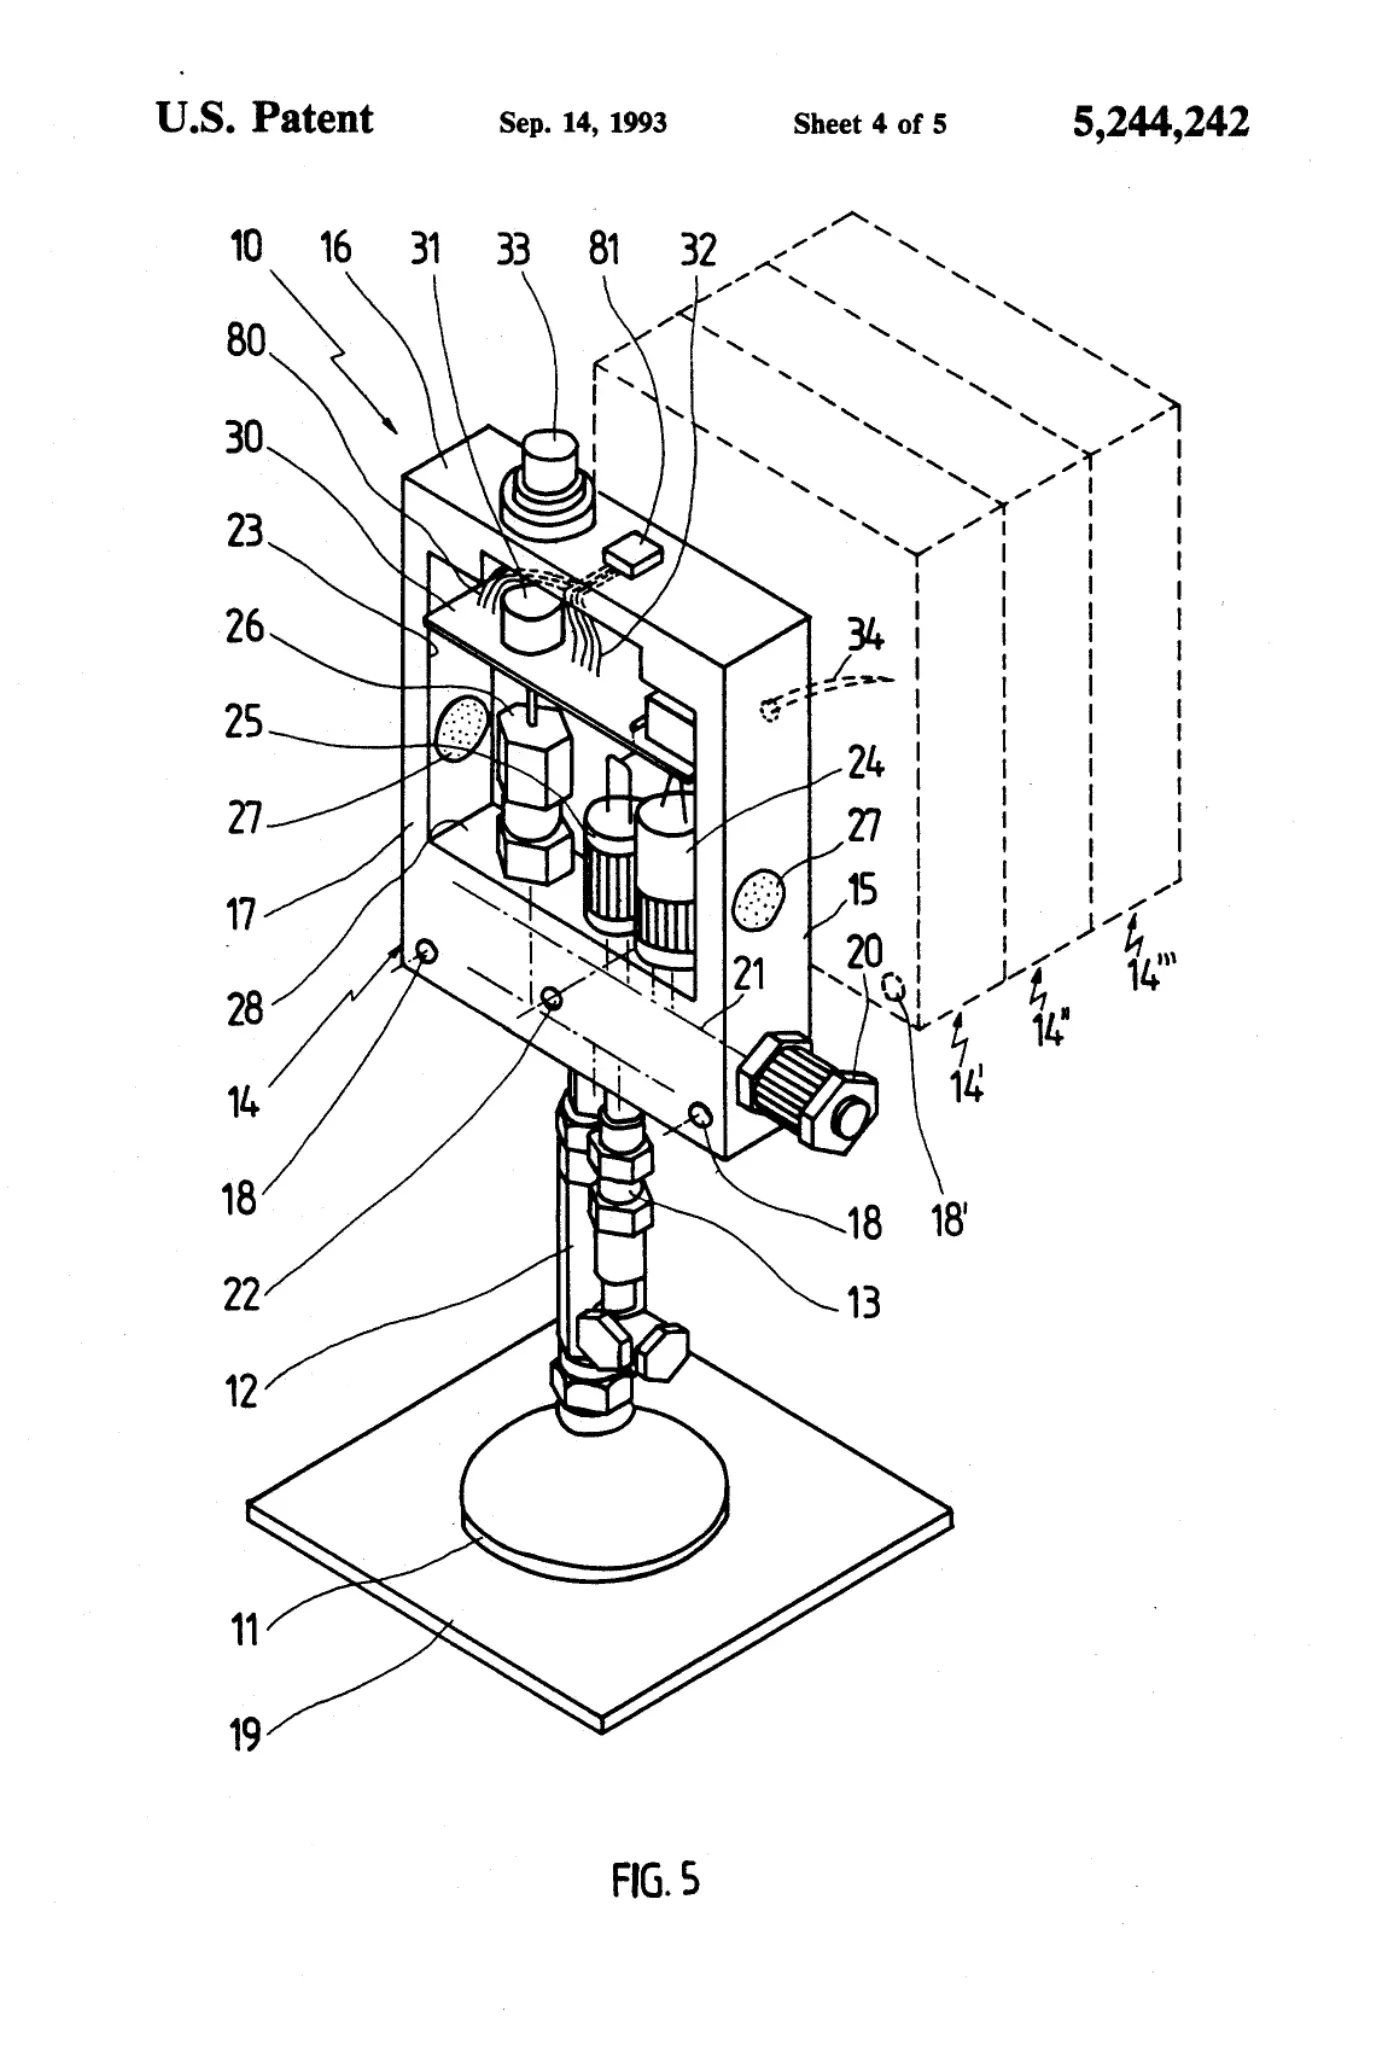
[0004]Sheet 4.
[0005]Sheet 5.
Publication information
Citation
OpenTechnical Publication OT-2026-000003367, “Manipulator with a suction gripper and method for handling and testing fluid-passing components,” published September 15, 2026 at 20:17:15 UTC, https://opentechnical.org/p/OT-2026-000003367.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.