OT-2026-000003279
Climber robot
- Published
- Permanent URL
- https://opentechnical.org/p/OT-2026-000003279
- Classification
- Robotics & Automation › End Effectors
- Assignee
- UNIV VANDERBILT
- Original source
- US-5551525-A, the United States Patent and Trademark Office, 3 September 1996
- Document SHA-256
- 6b5dad714eb863550ad357f0840f31ce63a190eeb01c01bb953bd37b79241784
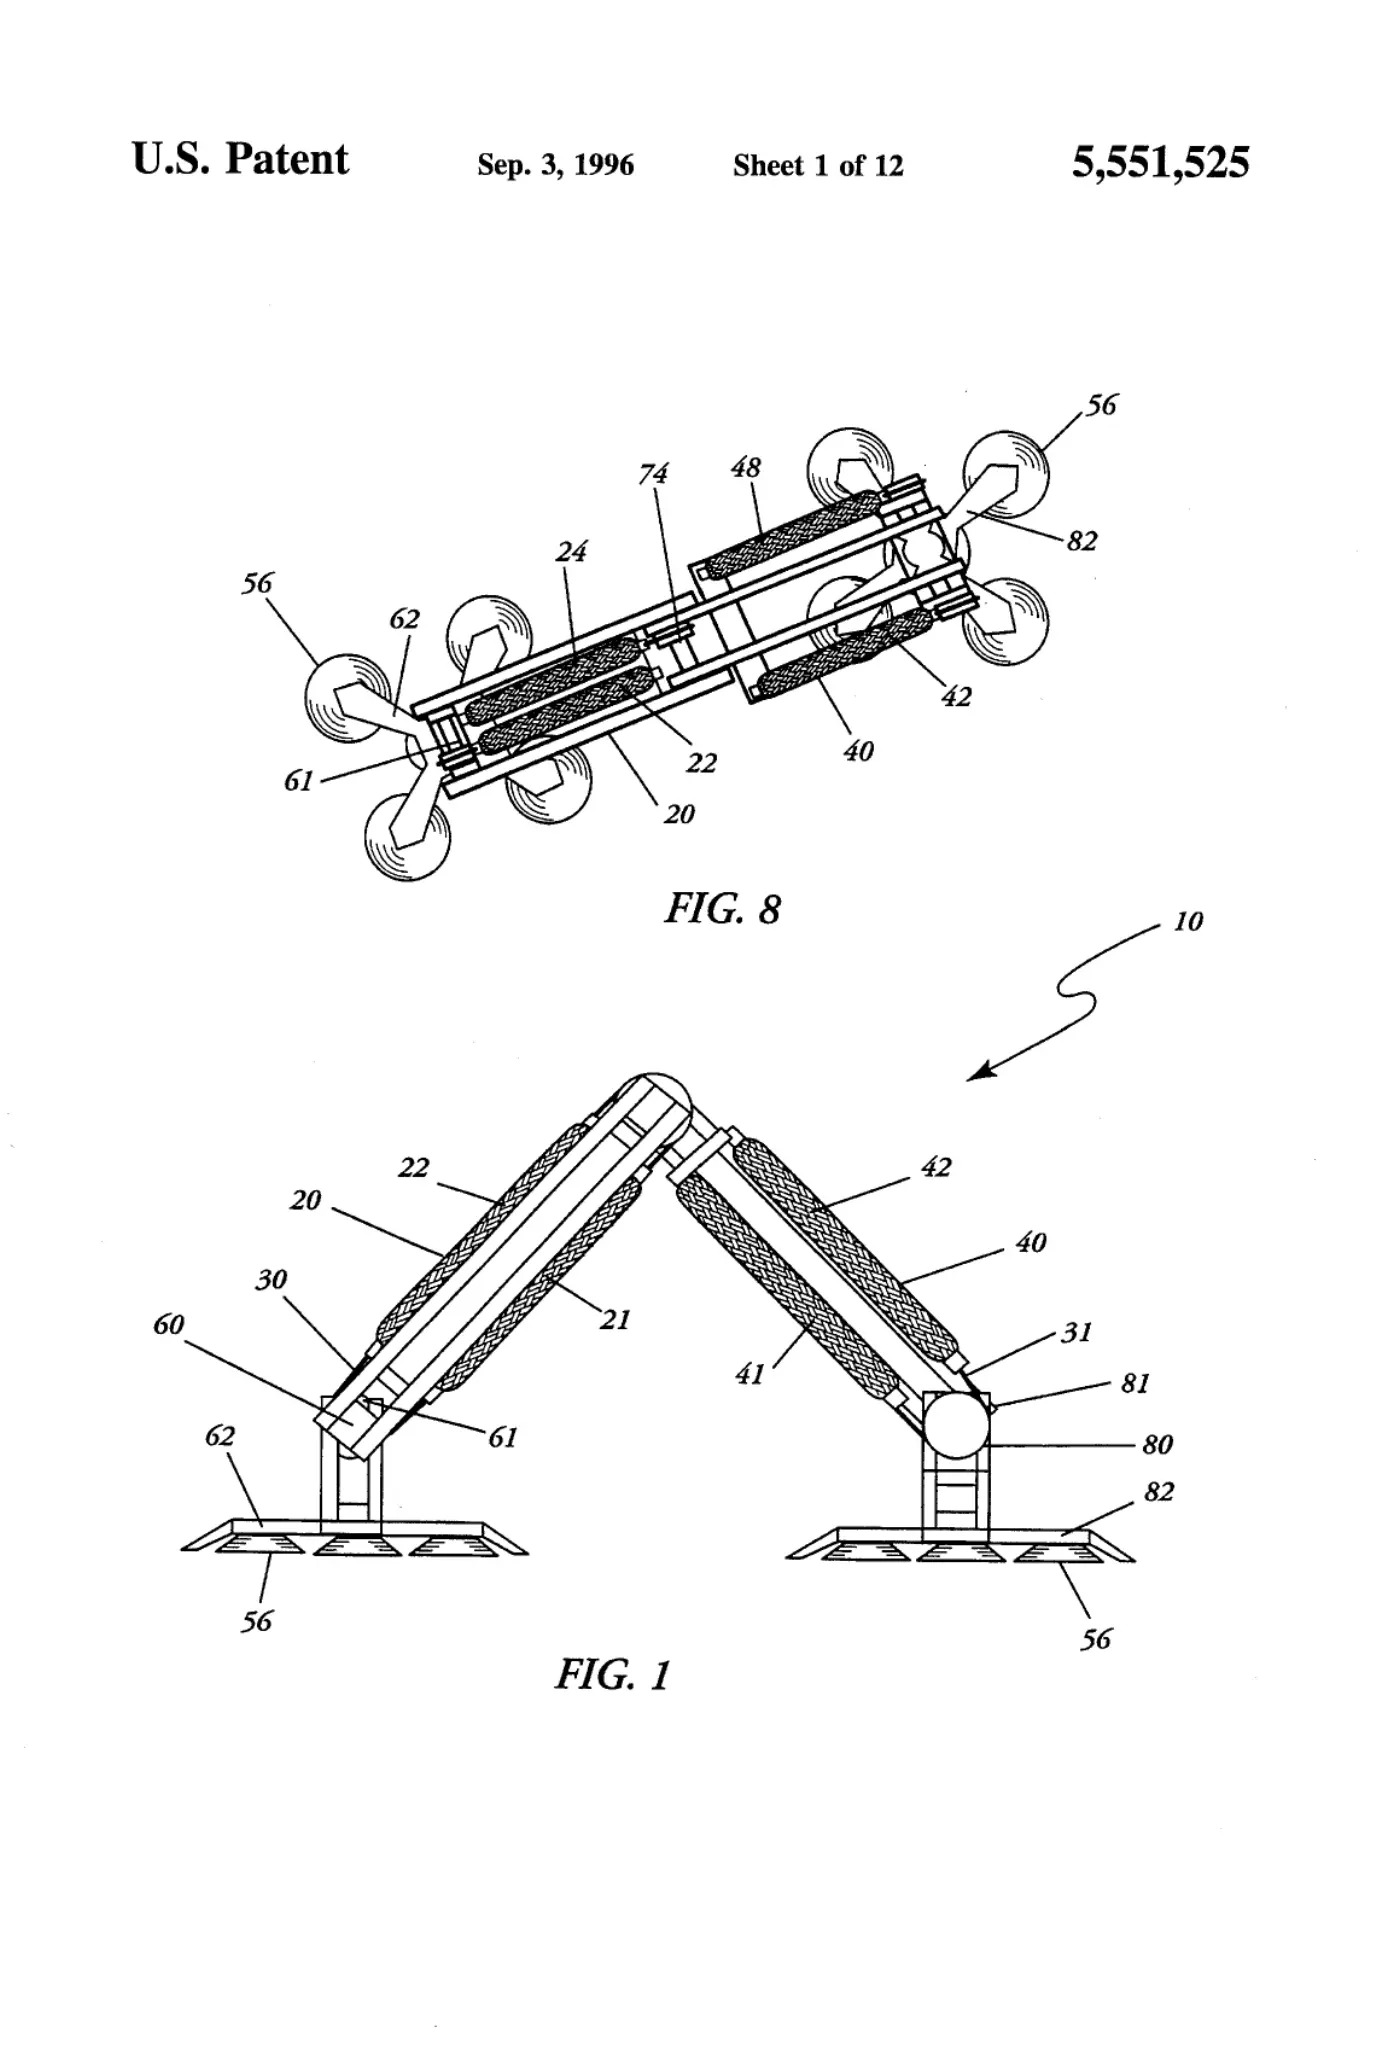
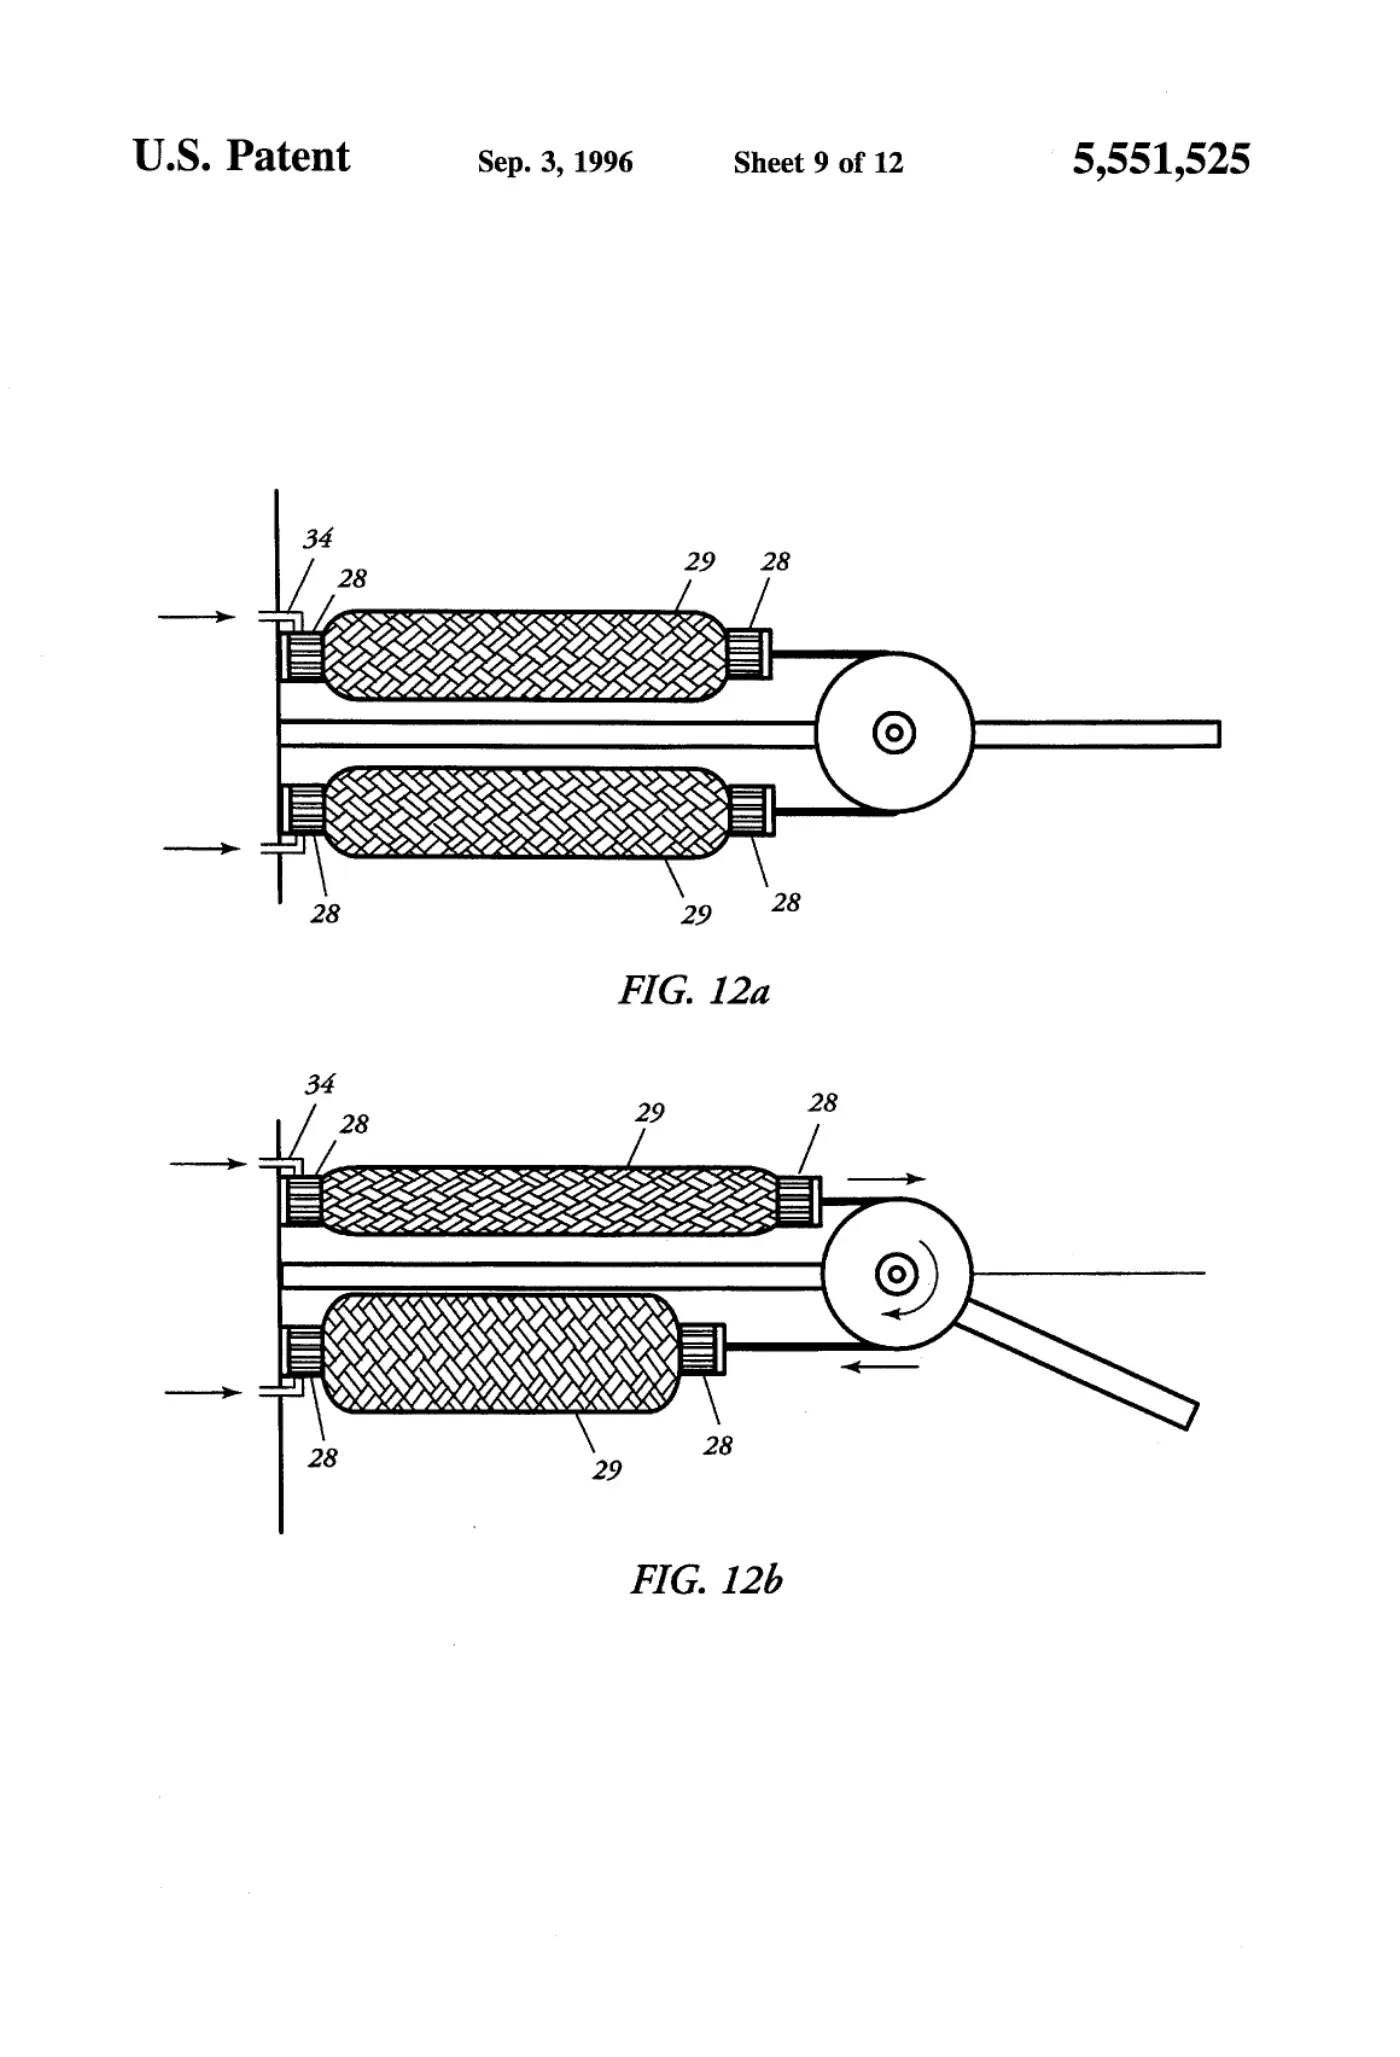
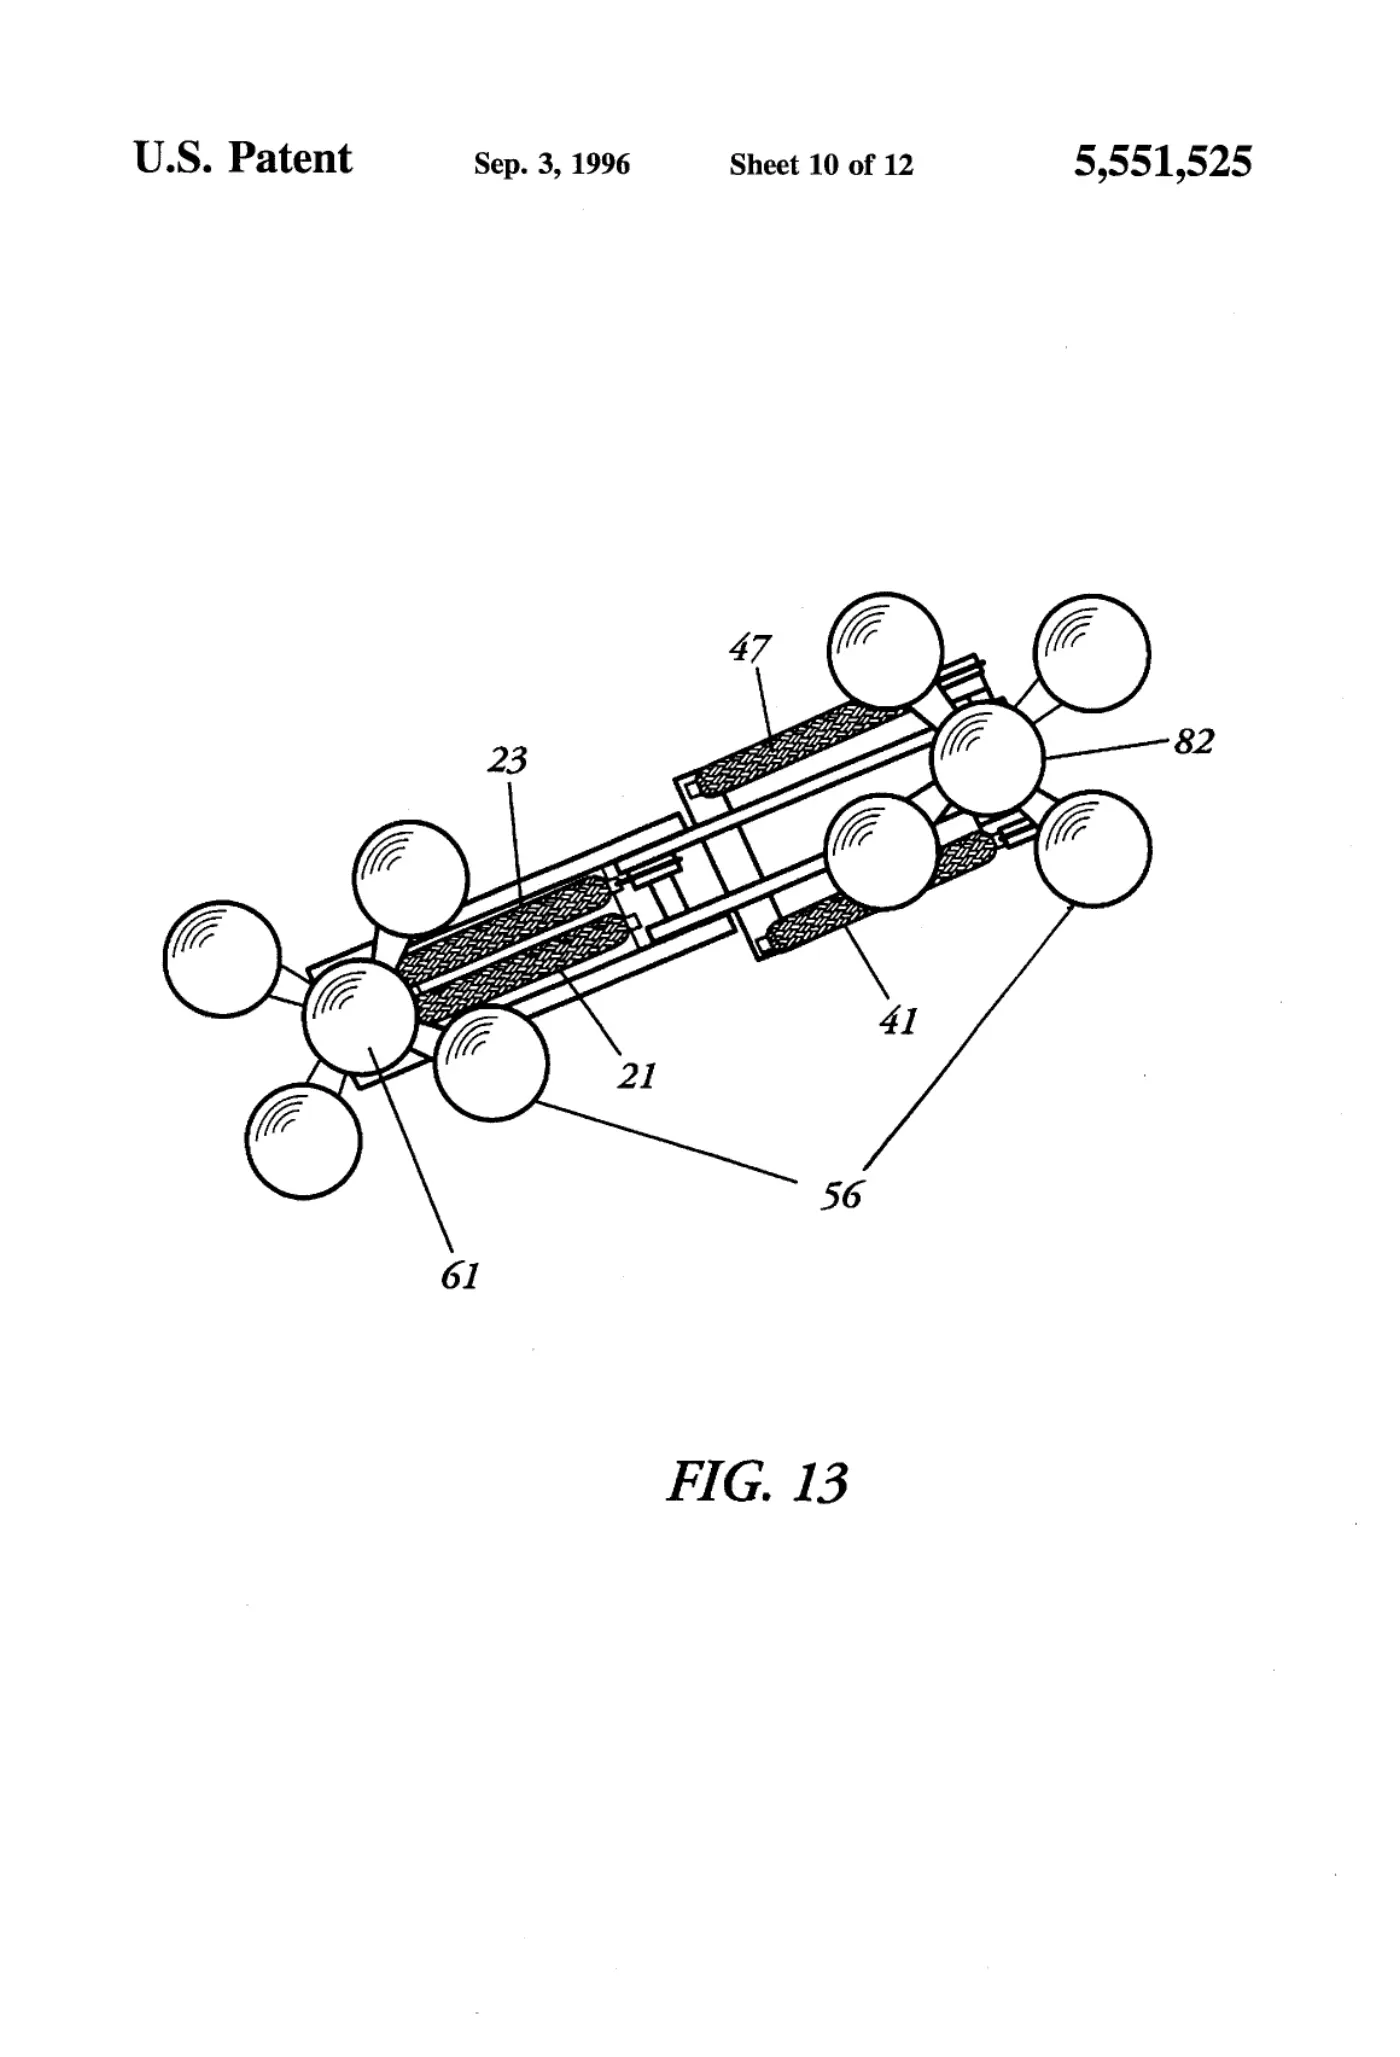
A climber robot has front and rear legs joined together by a pivoting knee joint and having pivoting ankle joints at their distal ends. Pneumatic muscle pairs attached to each leg allow the robot to move vertically and horizontally and make easy transitions over obstacles and from the horizontal to vertical plane.
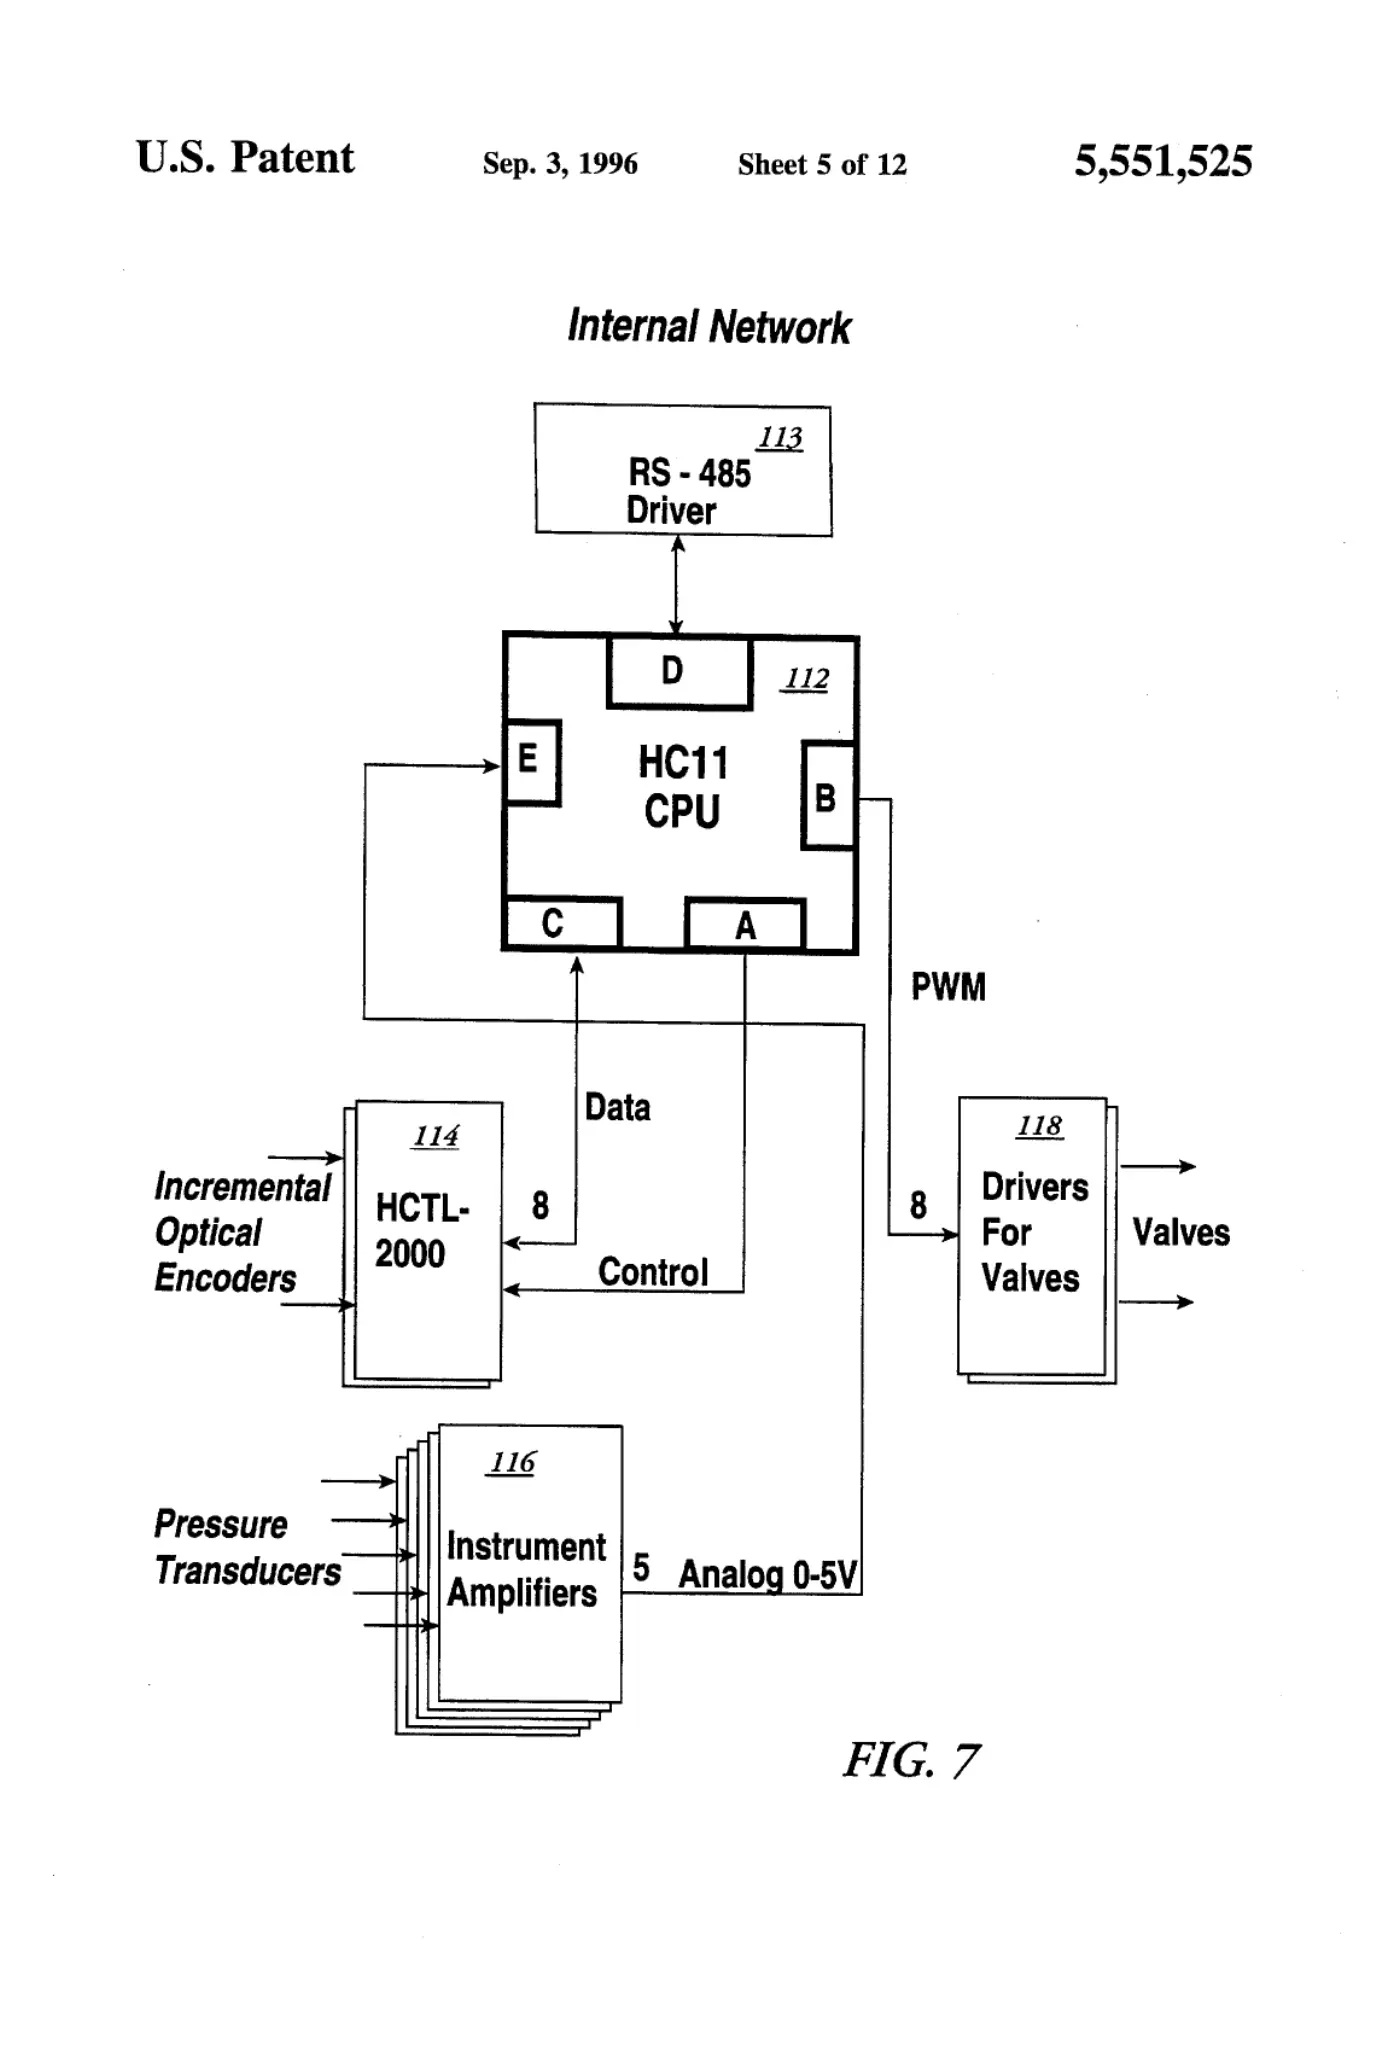
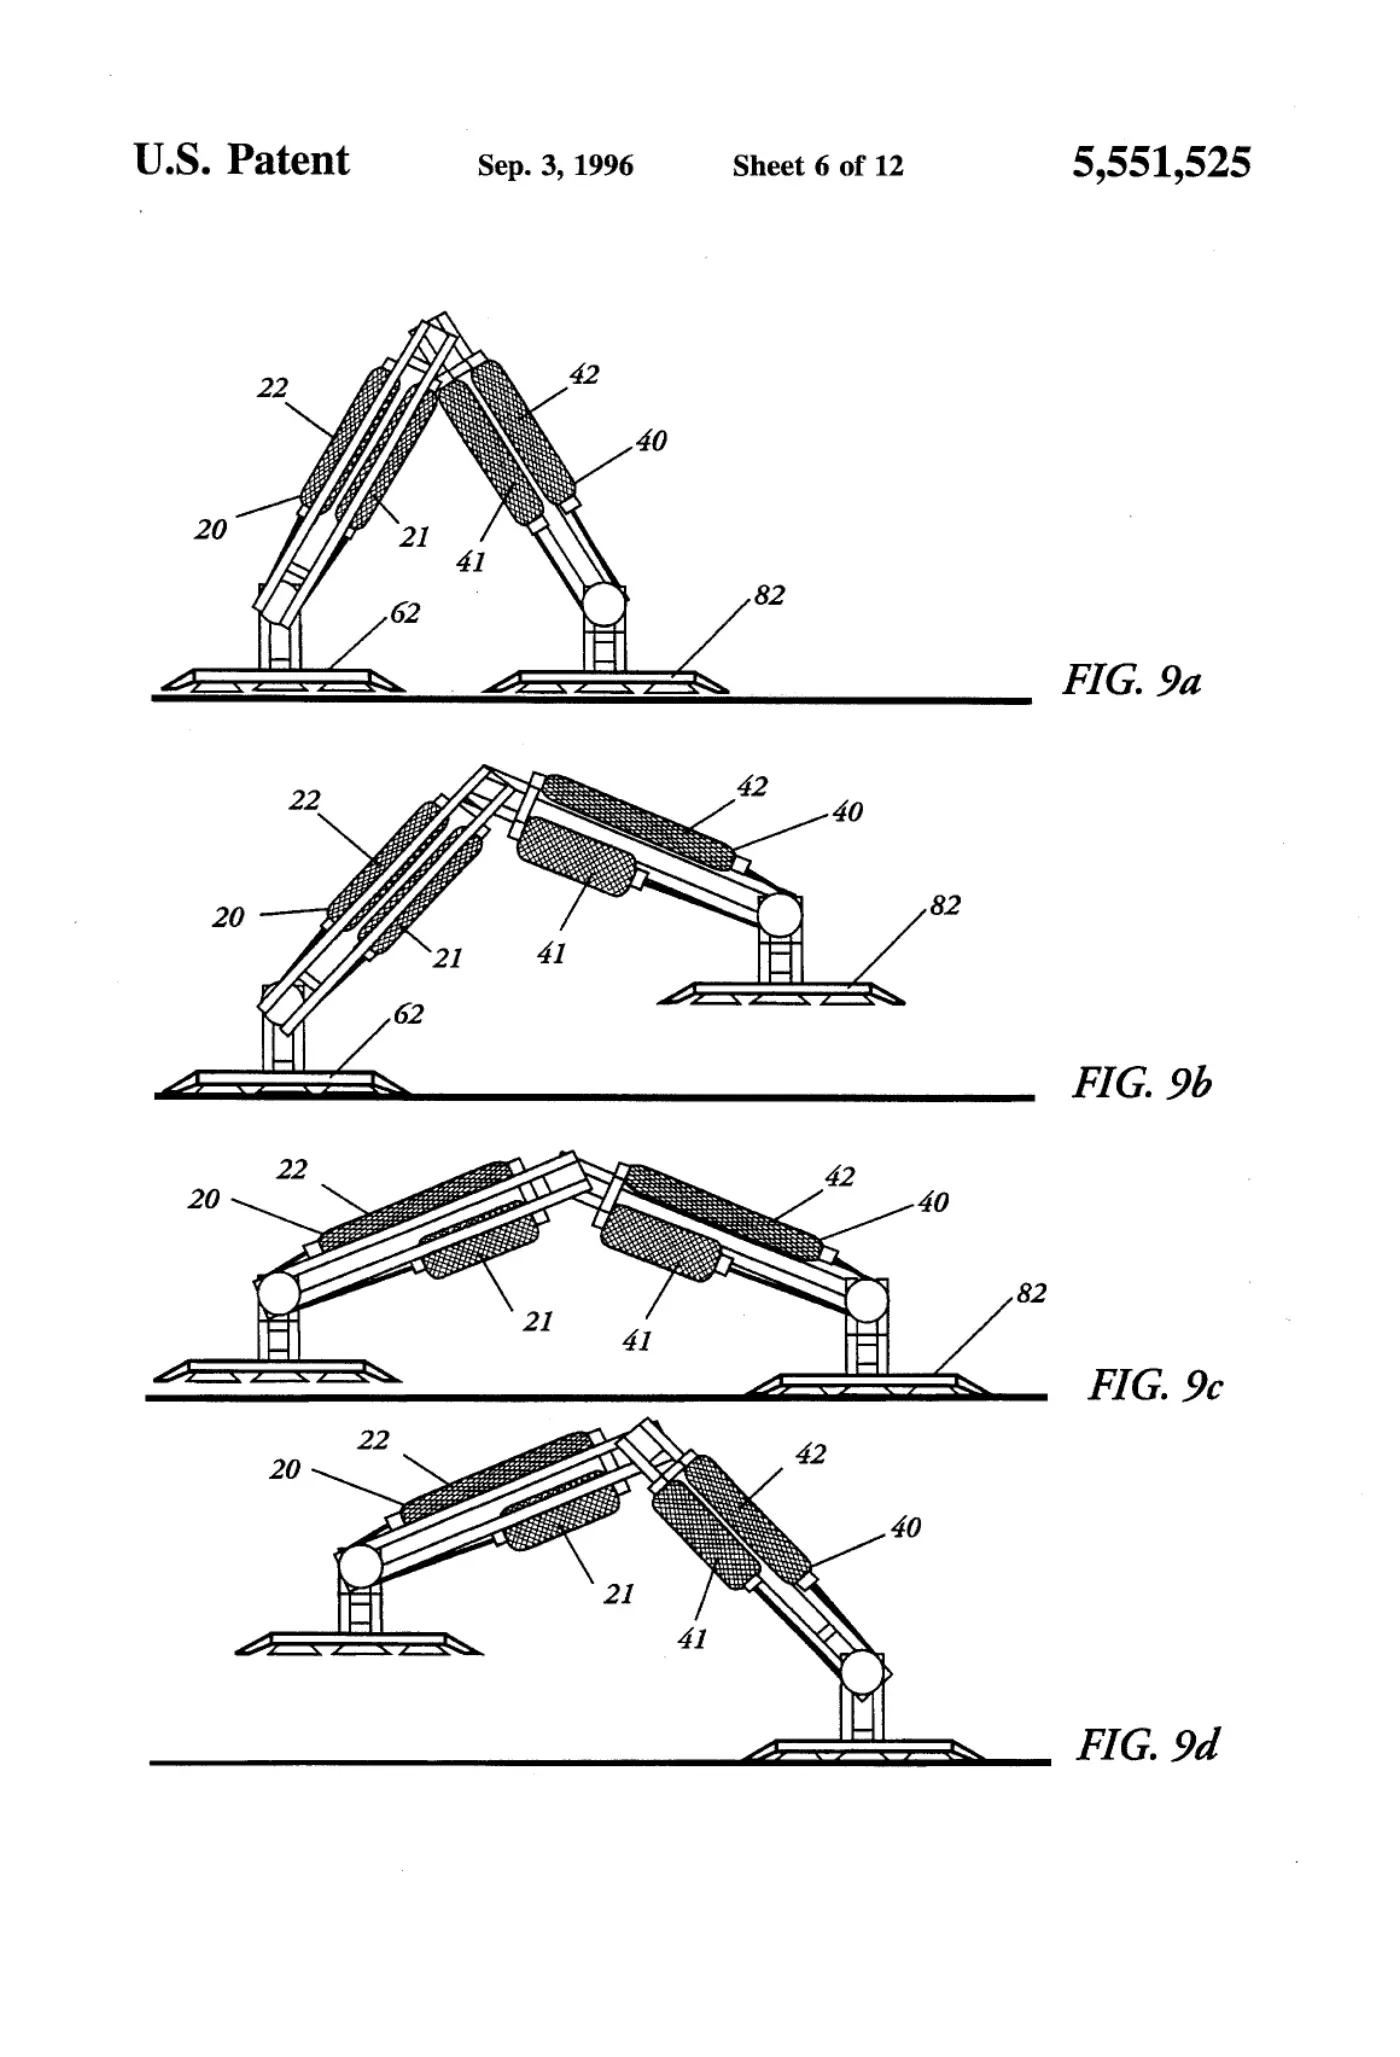
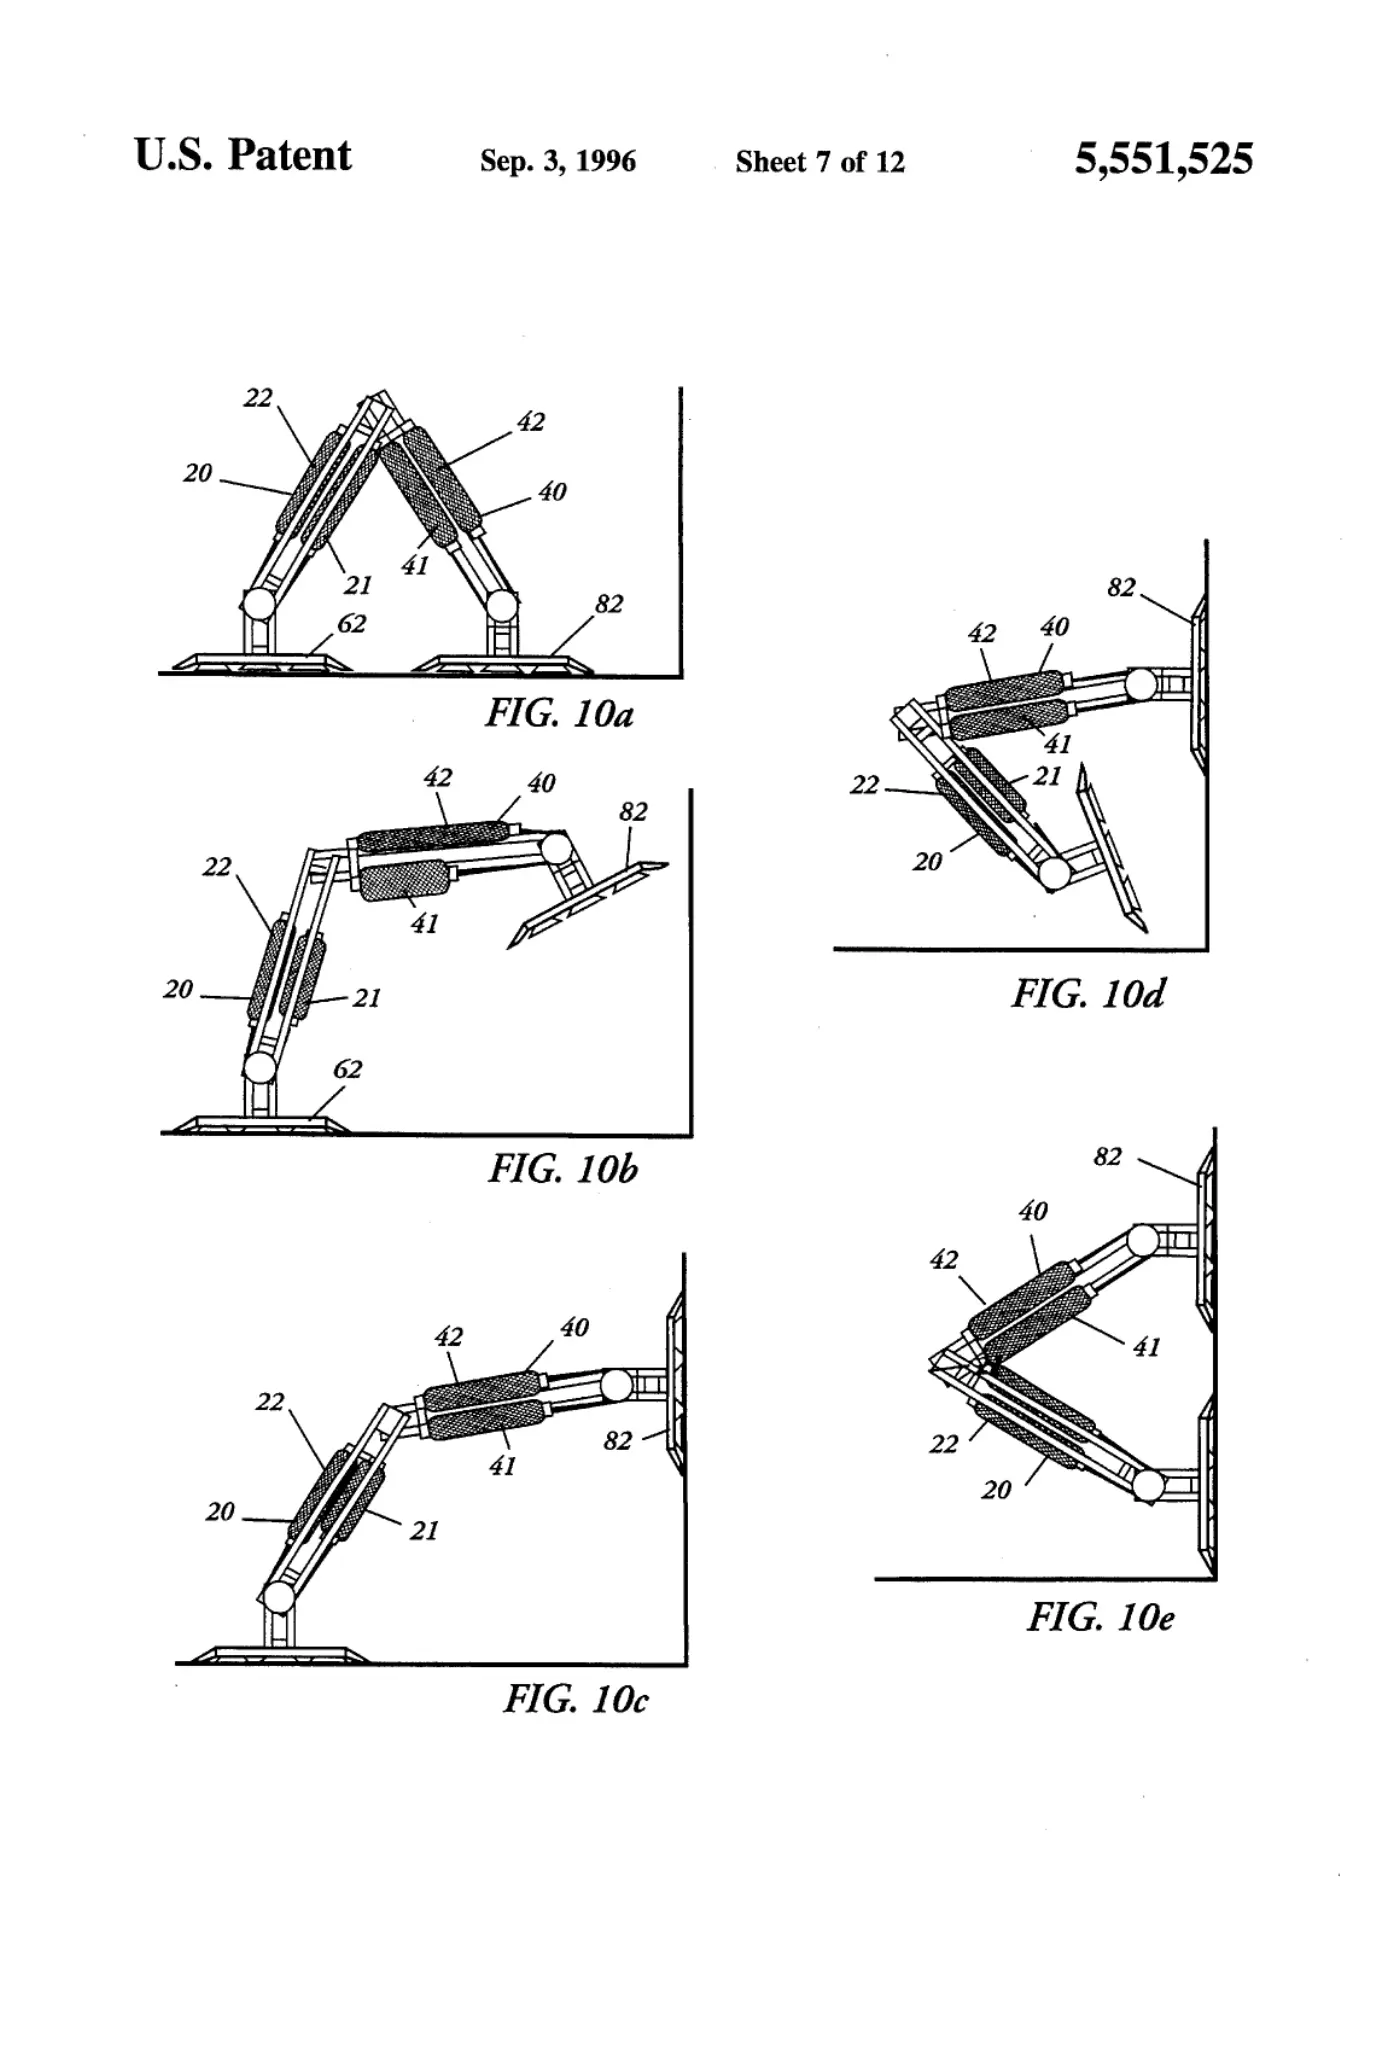
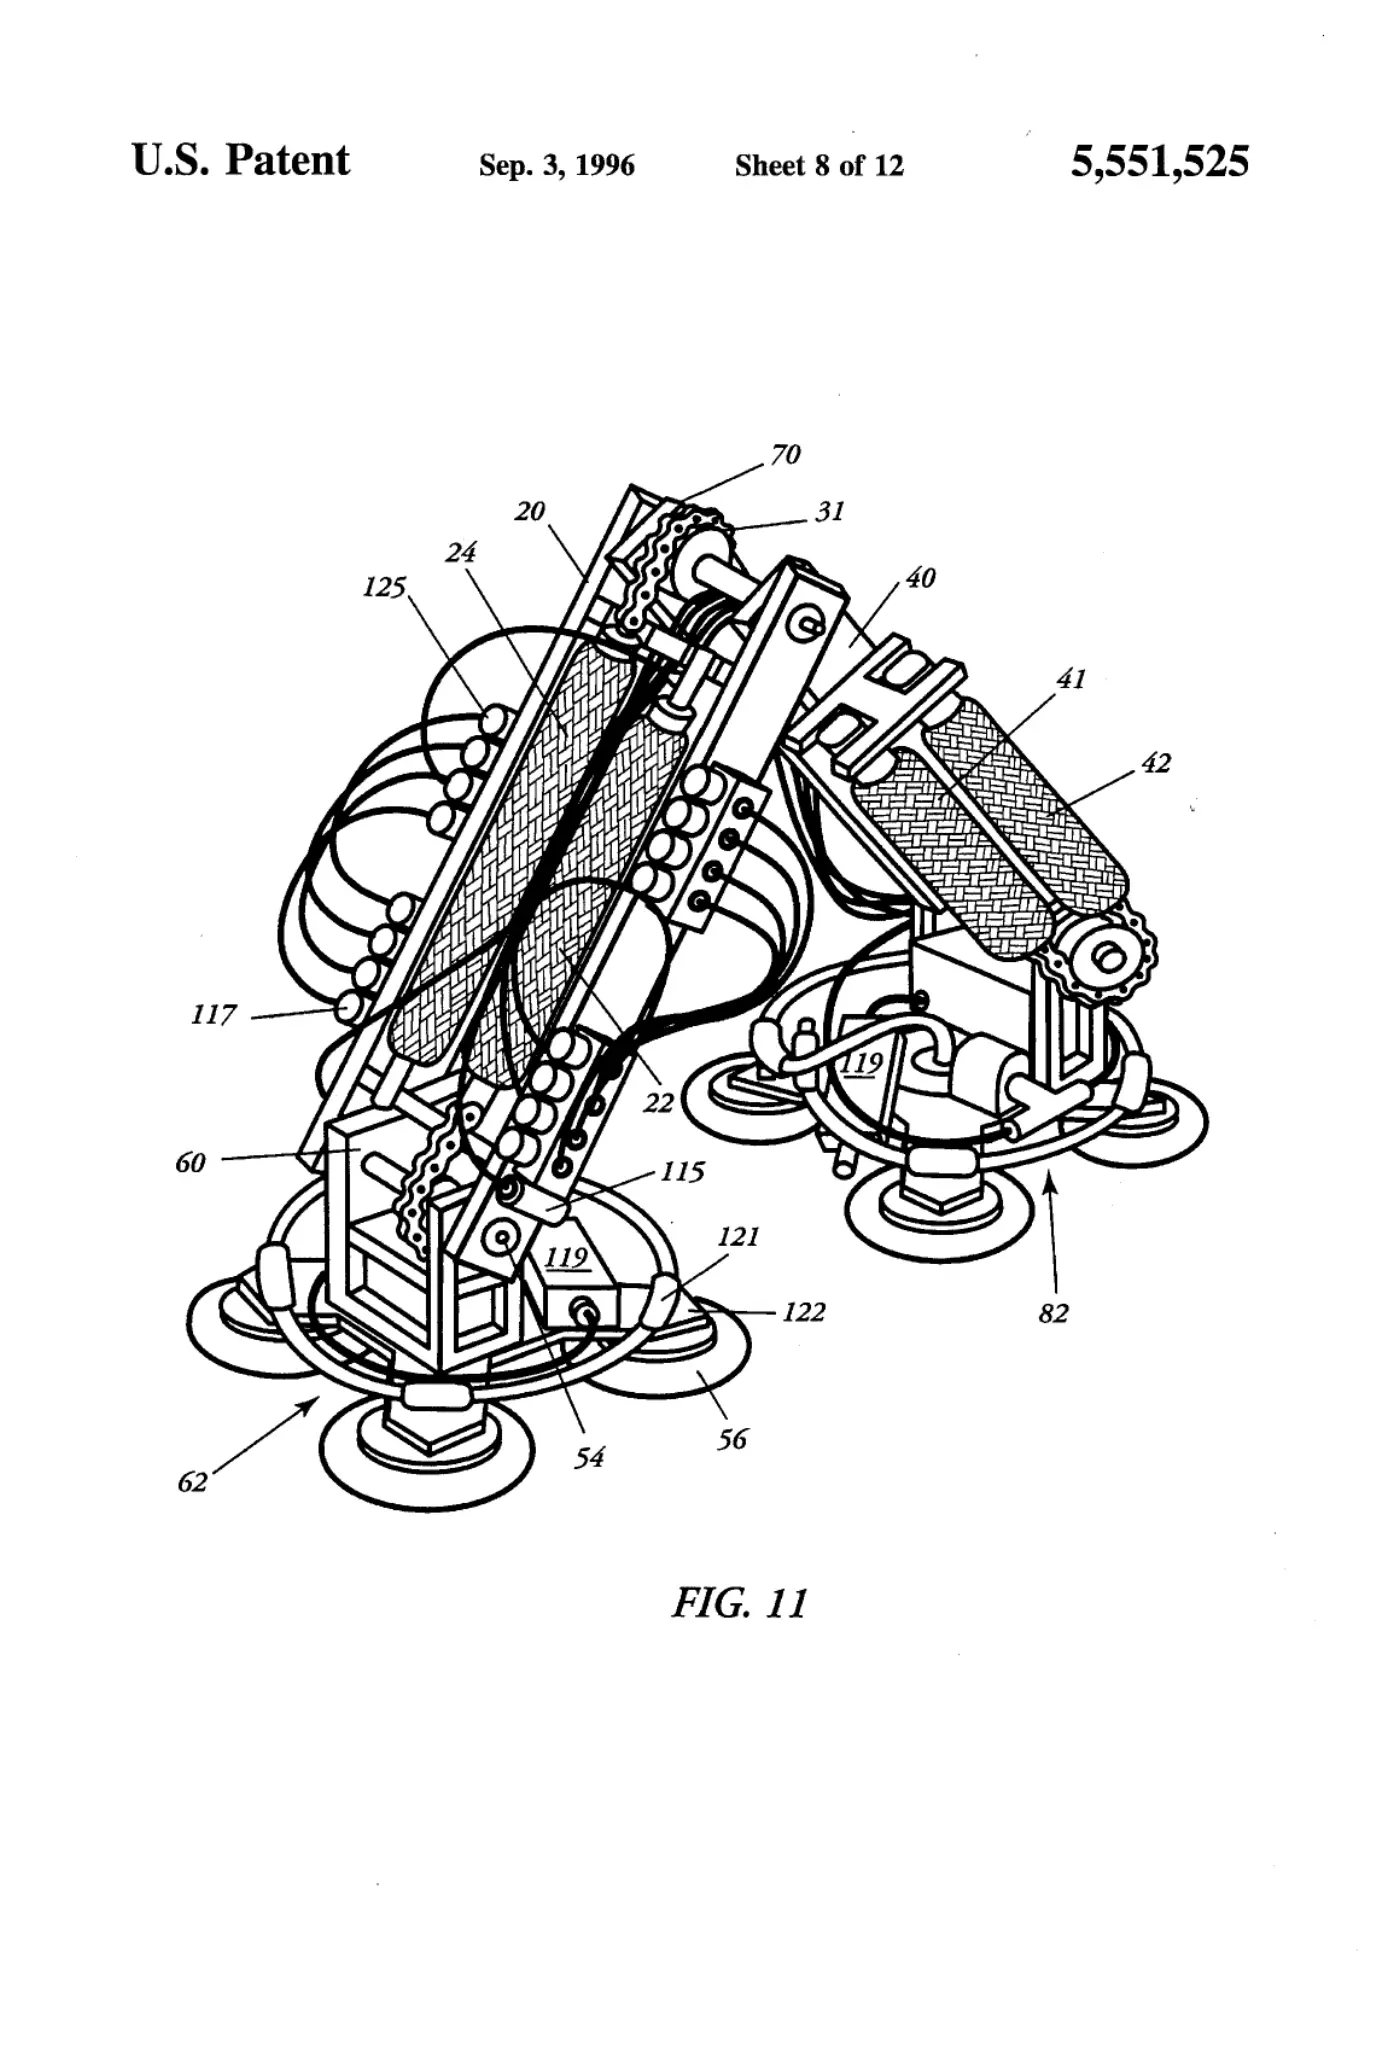
Abstract
A climber robot has front and rear legs joined together by a pivoting knee joint and having pivoting ankle joints at their distal ends. Pneumatic muscle pairs attached to each leg allow the robot to move vertically and horizontally and make easy transitions over obstacles and from the horizontal to vertical plane.
1. Drawings
[0001]Sheet 1.
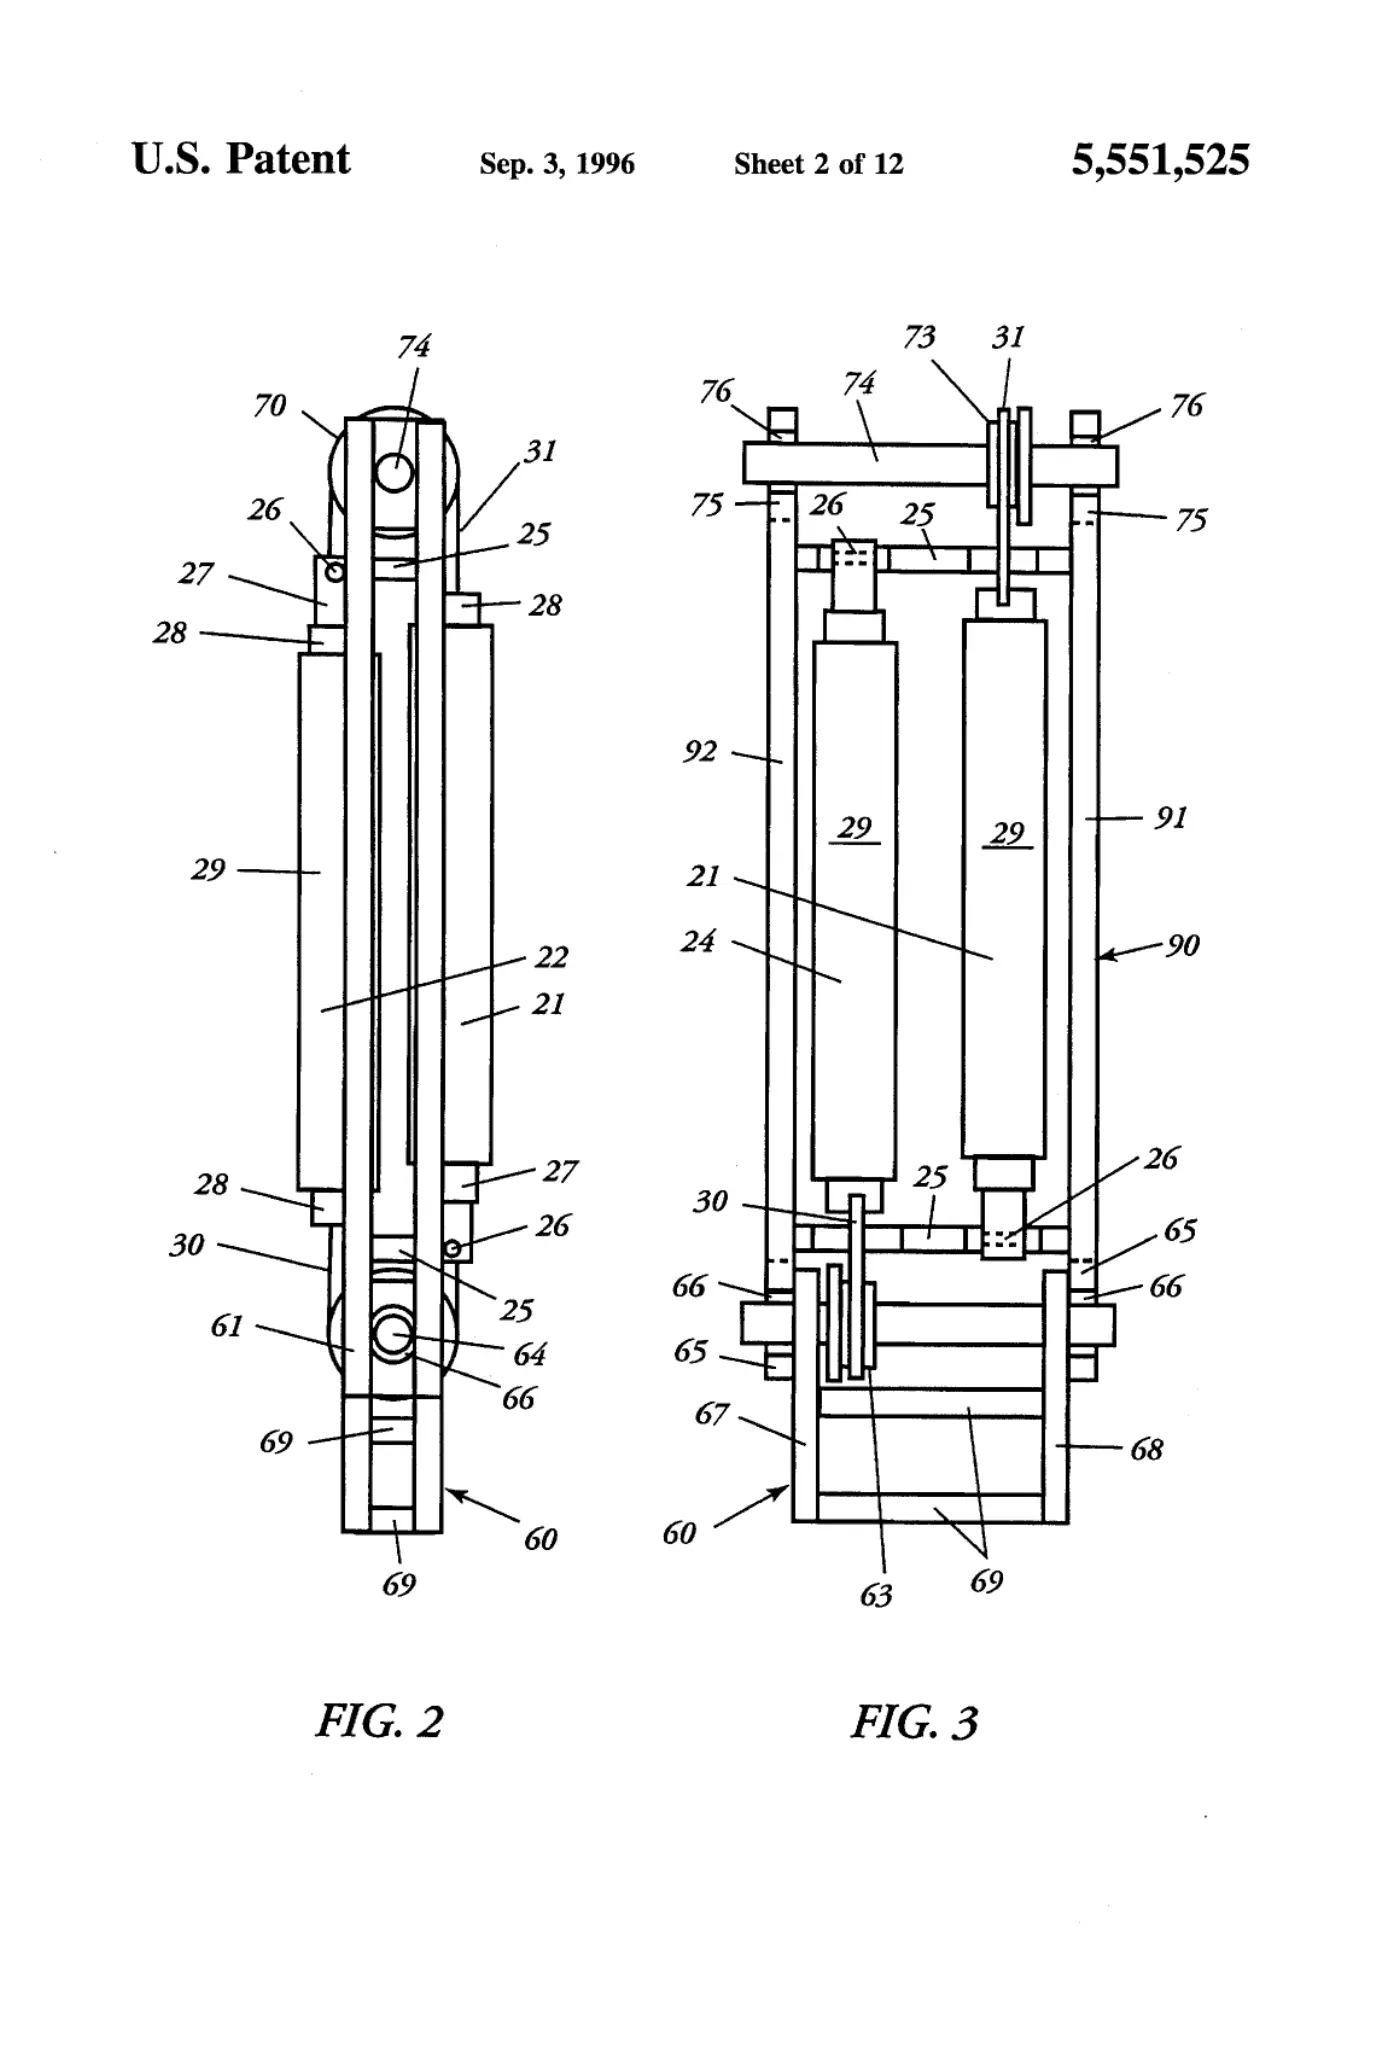
[0002]Sheet 2.
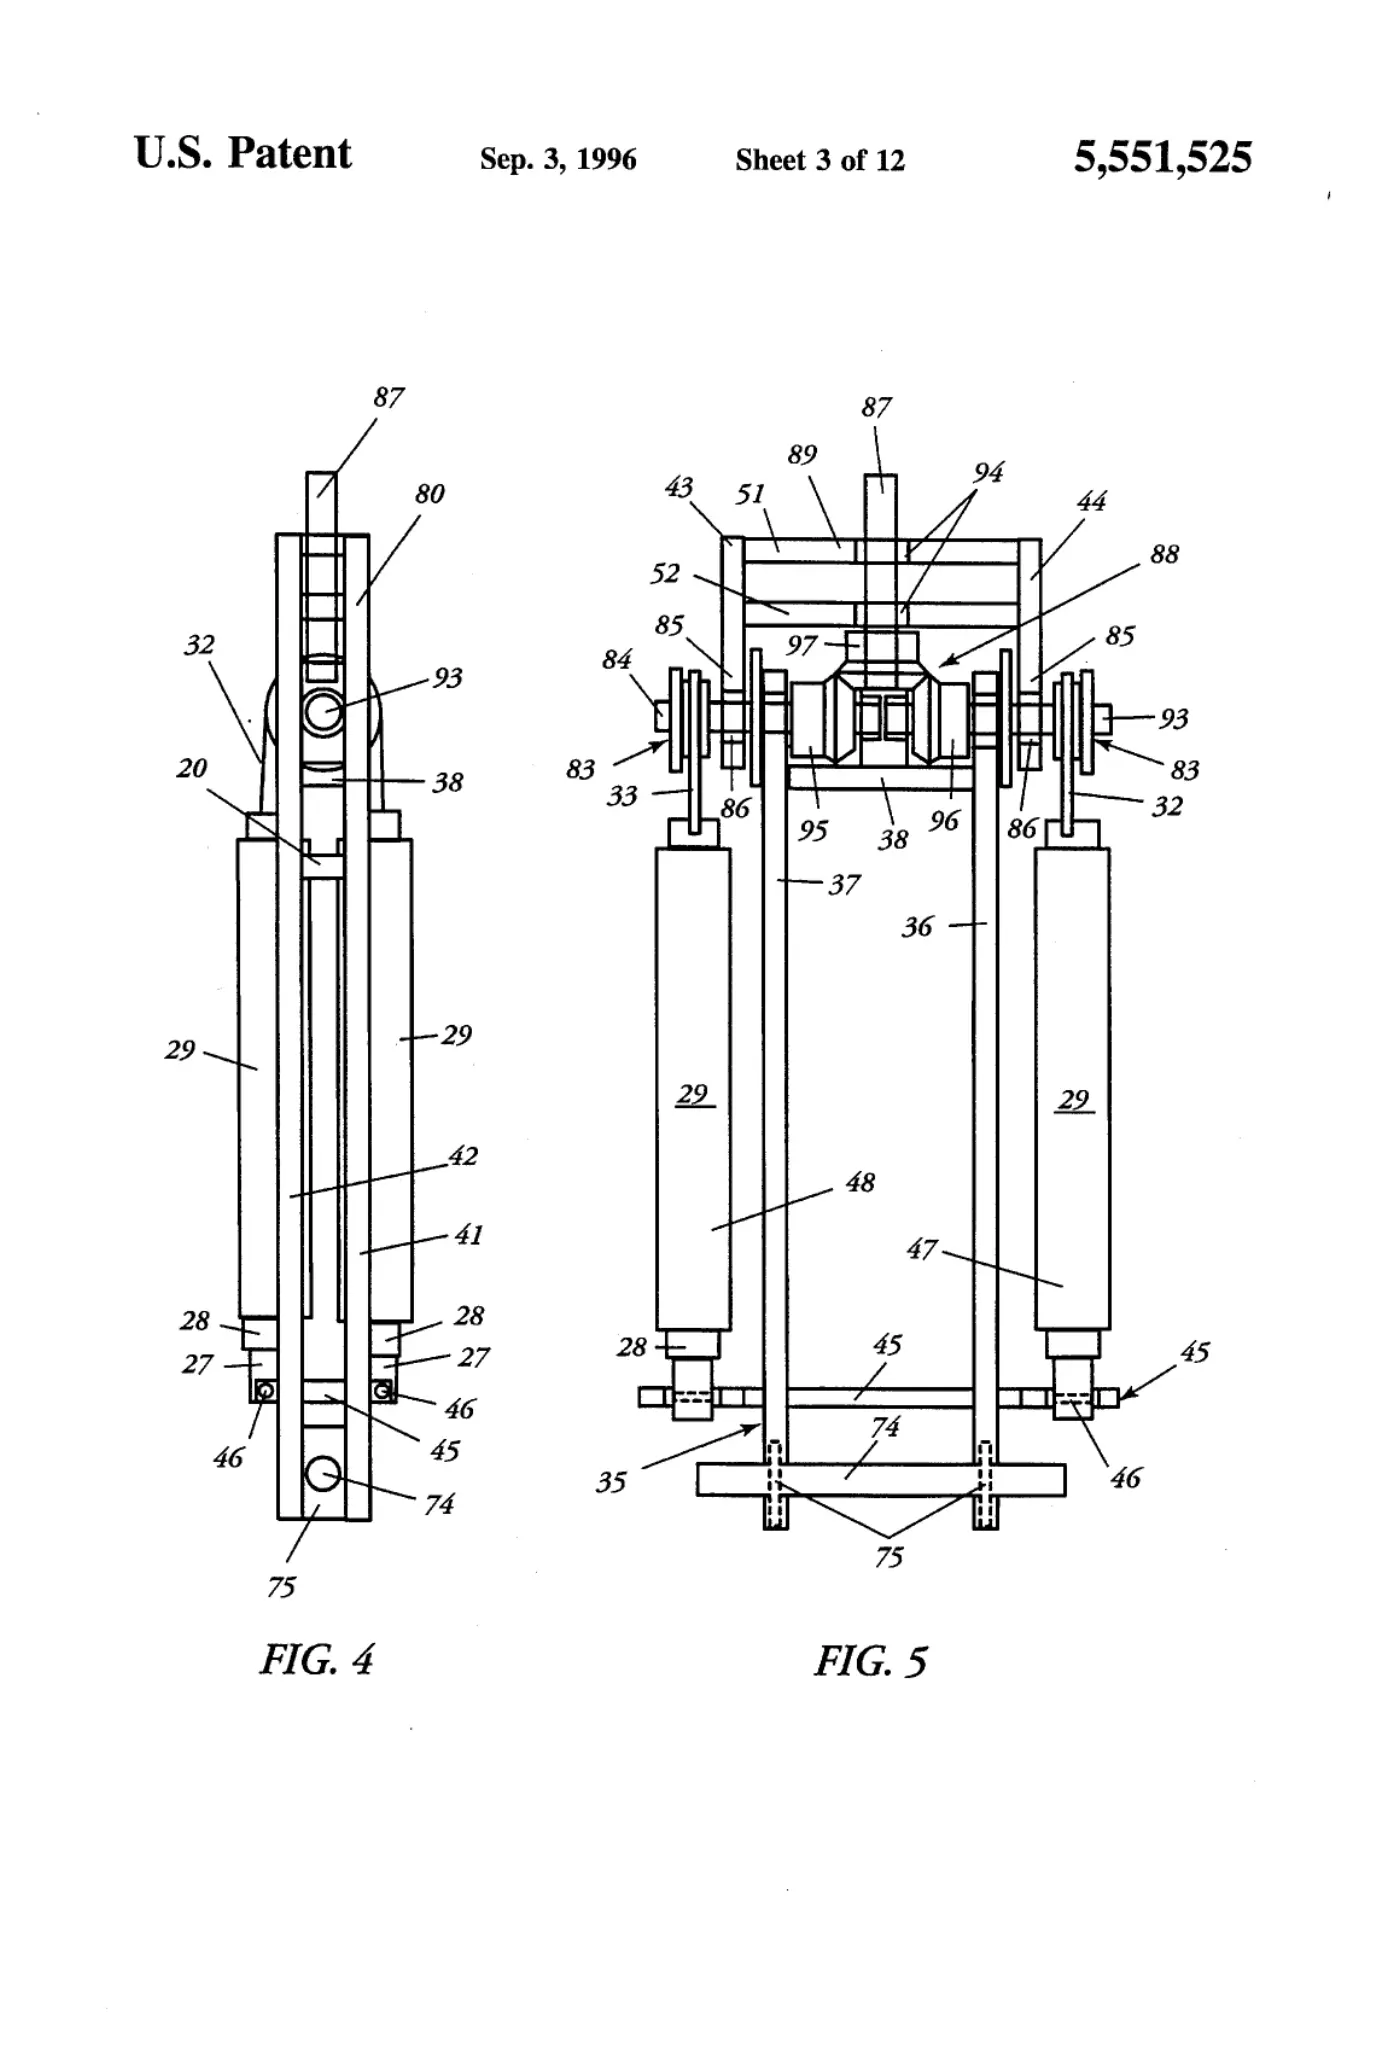
[0003]Sheet 3.
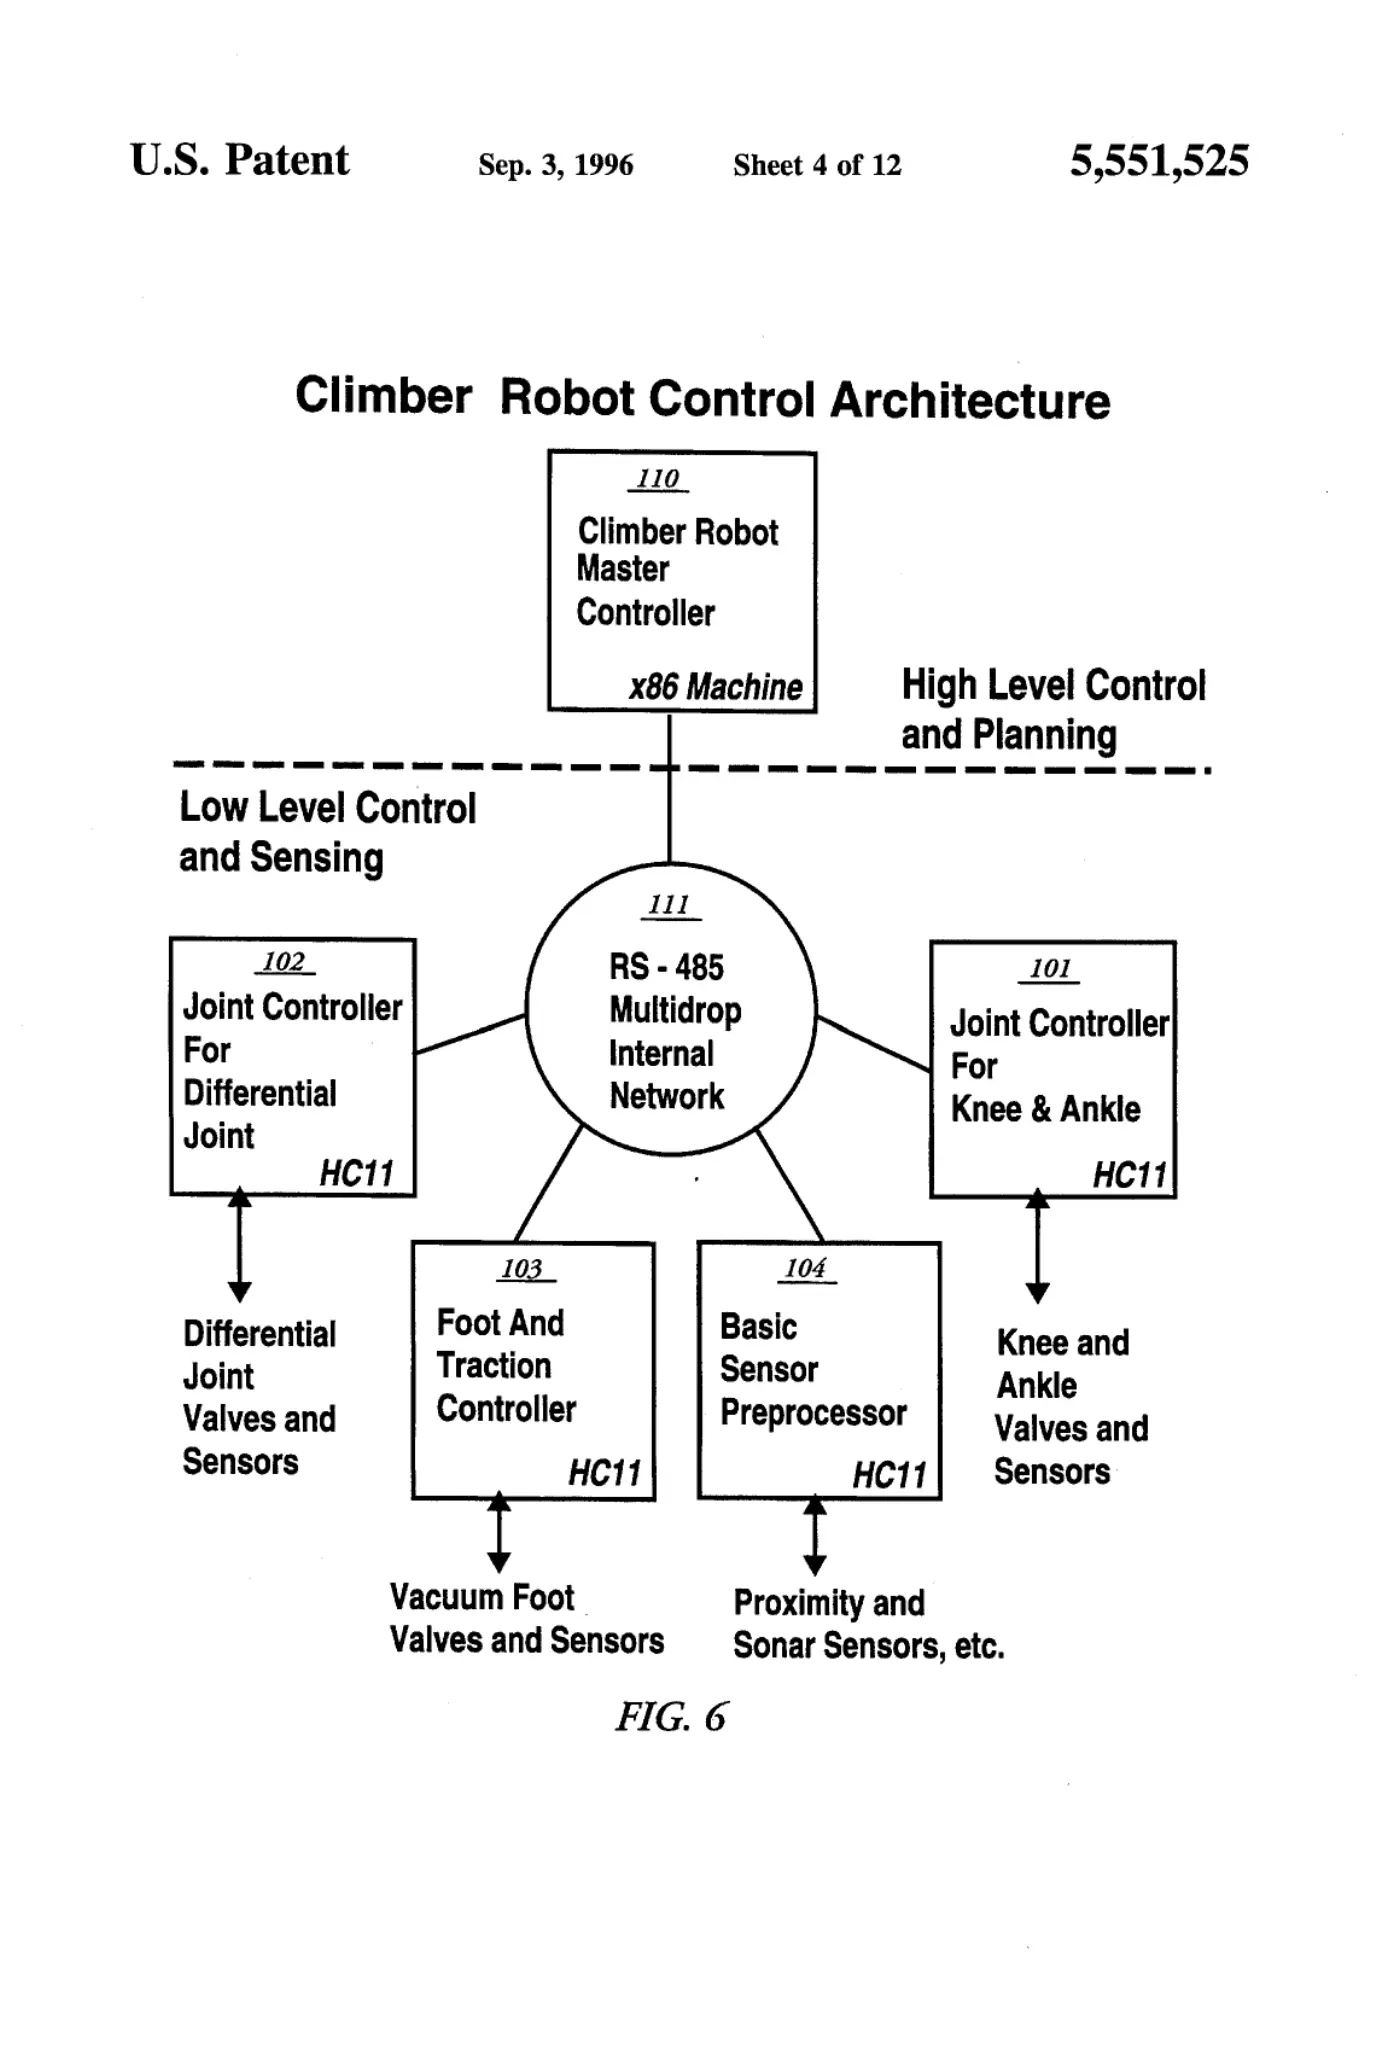
[0004]Sheet 4.
[0005]Sheet 5.
[0006]Sheet 6.
[0007]Sheet 7.
[0008]Sheet 8.
[0009]Sheet 9.
[0010]Sheet 10.
Publication information
Citation
OpenTechnical Publication OT-2026-000003279, “Climber robot,” published September 15, 2026 at 20:01:26 UTC, https://opentechnical.org/p/OT-2026-000003279.
To cite specific content, add the paragraph or figure numbers.
Terms
This record reproduces a document published elsewhere and is provided for reference and study. Rights in the original remain with its owner. See the publication policy.